EP3196379A1 - Infrastructure for controlling and moving a blade closure of a pergola or the like - Google Patents
Infrastructure for controlling and moving a blade closure of a pergola or the like Download PDFInfo
- Publication number
- EP3196379A1 EP3196379A1 EP16207180.7A EP16207180A EP3196379A1 EP 3196379 A1 EP3196379 A1 EP 3196379A1 EP 16207180 A EP16207180 A EP 16207180A EP 3196379 A1 EP3196379 A1 EP 3196379A1
- Authority
- EP
- European Patent Office
- Prior art keywords
- motor
- stroke
- blades
- microcontroller
- motors
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Granted
Links
Images
Classifications
-
- E—FIXED CONSTRUCTIONS
- E04—BUILDING
- E04F—FINISHING WORK ON BUILDINGS, e.g. STAIRS, FLOORS
- E04F10/00—Sunshades, e.g. Florentine blinds or jalousies; Outside screens; Awnings or baldachins
- E04F10/08—Sunshades, e.g. Florentine blinds or jalousies; Outside screens; Awnings or baldachins of a plurality of similar rigid parts, e.g. slabs, lamellae
- E04F10/10—Sunshades, e.g. Florentine blinds or jalousies; Outside screens; Awnings or baldachins of a plurality of similar rigid parts, e.g. slabs, lamellae collapsible or extensible; metallic Florentine blinds; awnings with movable parts such as louvres
Definitions
- the present invention relates to an infrastructure for controlling and moving a blade closure of a pergola or the like.
- pergolas which practically consist of rigid support structures generally having parallelepiped shape and involved on the top wall, and sometimes also on the side walls, by movable blade closures.
- Each closure comprises a plurality of parallel blades, which may be moved both by translating movement perpendicular to the longitudinal axis thereof, to pass from an unfolded or closed condition to a packed or open position, and by rotating motion about the longitudinal axis thereof to be oriented according to the shielding effect which is to be obtained therewith.
- they may be simultaneously oriented for an angular range slightly less than 90° in order to pass from a substantially coplanar arrangement for intercepting the light to a substantially parallel arrangement for letting the light pass.
- Pergolas are also known, such as the one described in AU 2007 237309 , in which the blades are solely moved rotatingly about the longitudinal axis thereof, without the possibility of being moved in a translating manner.
- translation is used to define the movement which causes the blades to pass from an open configuration (blades unfolded) to a closed configuration (blades packed) and vice versa
- rotation is used to define the movement which causes the blades to be orientated about the longitudinal axis thereof to allow more or less light to pass therebetween.
- the translation of the blades should be allowed only when they are arranged parallel to one another, while it should be avoided when the blades are oriented differently.
- EP 2868833 describes a pergola in which the cover is defined by a plurality of blades and in which both the motor for the translating movement of the blades and the motor for the rotating movement of the blades are managed by a same control unit.
- two position sensors which are conveniently mounted on the support structure of the pergola, and therefore are external to the two motors, are provided for detecting if the blades are coplanar (and therefore in the closed condition) and if the cover is in the open condition (i.e. if the blades are unfolded and spaced apart from one another), respectively. These sensors then generate corresponding signals which are sent to the control unit which is conveniently installed inside an upright of the support structure of the pergola.
- the position sensors are to be connected to the control unit, to which the two motors are also connected, and this requires a series of wire assemblies which may require a laborious installation and even more laborious modifications in the infrequent case in which the position of the control unit is to be moved.
- the infrastructure according to the invention may be used to control the two motors which perform the translating and rotating movements of a blade closure of a pergola or the like.
- the blades 2 of pergola 4 are actuated in translation by a first motor 6 through a first control unit 8 to which first detection means 10 of the current supplying the motor itself, are associated.
- the blades 2 are actuated in rotation about the longitudinal axis thereof, by a second motor 12 through a second control unit 14 to which second detection means 16 of the current supplying the motor itself, are associated.
- the two motors 6 and 12 are provided with internal stroke ends which are electrically connected with the respective control units 8 and 14, which control the supply current to be sent to the input of said motors.
- each motor is connected to the respective control unit so that at the stroke-end positions thereof, the corresponding control unit interrupts the current which supplies the motor itself.
- the two management units 8, 14 and the respective detection means 10, 16 of the current absorbed by the motors 6 and 12 are connected to a microcontroller 18.
- the detection means 10, 16 of the current which supplies the motor comprise sensors which measure the absorption of current by the motor itself.
- control units 8 and 14 comprise suitable electronic circuits which control and/or interrupt the supply current 39 to be sent to the input of the corresponding motors 6 and 12.
- the electronic circuit of the control unit 8 comprises a first relay 40, which is associated with the "open" terminal for the rotation of the motor in a first direction, and a second relay 41, which is associated with the "close” terminal for the rotation of the motor itself in the opposite direction.
- a third safety relay 42 is also provided, associated with the terminal of the common of motor 6.
- sensor 10 Associated with the terminal of the common of motor 6, preferably in series with the third relay 42, is sensor 10 which detects the current absorption by the motor itself.
- this sensor 10 is galvanically isolated between input and output and furthermore, the output thereof is connected to microcontroller 18 by means of an operational amplifier 44.
- the two management units 8, 14, the respective detection means 10, 16 and microcontroller 18 are installed or incorporated in a same electronic board 20.
- an electronic board 20 is applied to or incorporated in the control unit for managing the whole infrastructure or pergola.
- Associated with the microcontroller 18 itself is also a radio receiver 24, by means of which controls may be imparted to the microcontroller itself by means of a remote control.
- the infrastructure according to the invention also comprises detection sensors of specific atmospheric quantities which are connected to the microcontroller 18 input in order to automatically affect the operation of the infrastructure.
- an input 26 for an external rain sensor, an input 28 for an external wind sensor and/or an input 30 for an external temperature sensor are connected to microcontroller 18.
- a memory 32 configured to store therein the position data of the motors 6 and 12 and the remote control codes, is also connected to microcontroller 18.
- a programming button 34 and a plurality of cabled control buttons 36 are associated with microcontroller 18.
- Microcontroller 18 is configured to act on the corresponding control units 8 and 14 on the basis of the supply current values detected by said detection means 10 and 16, and to selectively enable/disable the operation of said first motor 6 or said second motor 12.
- enabling the operation of each motor is performed by sending a suitable signal at the common terminal of each motor, while the successive actuation of each motor is performed by sending a suitable signal at the "open” or “close” terminal of the motor itself.
- the motors 6, 12 cannot be actuated in the "open” or “close” direction unless they were enabled to operate beforehand by means of the sending of a suitable signal at the common terminal of the corresponding motor.
- first 6 and second motor 12 when said first 6 and second motor 12 are enabled to operate, they are in a state in which a suitable successive control, which is imparted via radio and is connected by receiver 12, or is imparted via cable by means of a corresponding button 36, may induce the actuation of the corresponding motor.
- a suitable successive control which is imparted via radio and is connected by receiver 12, or is imparted via cable by means of a corresponding button 36.
- the blades 2 are unfolded, and i.e. they are arranged in open configuration (cfr solid lines in fig. 2 ) and they are oriented so as to be parallel to one another.
- the first motor 6 is at open stroke end and in such a condition, the corresponding first unit 10 is actuated to control the interruption of the supply current to the first motor 6.
- the detection means 10 detect the interruption of the current supply to the first motor 6 and send a corresponding signal to microcontroller 18 which enables the second motor 12 to operate so that a suitable control imparted via radio and collected by receiver 24 or imparted via wire by means of a corresponding button 36, may actuate the rotating movement of the blades 2 in the desired manner between the two stroke-end positions thereof, which correspond to the substantially parallel arrangement of the blades 2 and to the substantially coplanar arrangement thereof.
- the second unit 14 is actuated to control the interruption of the supply current to the second motor 12. Then, the second detection means 16 detect the interruption of the current supply to the second motor 12 and send a corresponding signal to microcontroller 18.
- microcontroller 18 only when microcontroller 18 receives the interruption signal of the current supply to the second motor 12 from the second detection means 16 following the reaching of the stroke-end position corresponding to the parallel arrangement of the blades 2 does the microcontroller itself enable the first motor 6 to operate so that when it receives a suitable control, via radio or via cable as seen above, it actuates the translating movement of said blades 2 - which were previously arranged parallel to one another - in the direction of the packing thereof.
- microcontroller 18 disables the operation of the second motor 12, which therefore can no longer move the blades in the direction of the rotation thereof, not even if a corresponding control should be imparted.
- microcontroller 18 is programmed so that:
Landscapes
- Engineering & Computer Science (AREA)
- Architecture (AREA)
- Civil Engineering (AREA)
- Structural Engineering (AREA)
- Control Of Multiple Motors (AREA)
- Power-Operated Mechanisms For Wings (AREA)
- Rehabilitation Tools (AREA)
- Toys (AREA)
- Structures Of Non-Positive Displacement Pumps (AREA)
Abstract
- a first motor (6) for the translating movement of said blades (2) between a first stroke-end position, wherein the blades are unfolded in open configuration, and a second stroke-end position, wherein the blades are packed in closed configuration,
- a second motor (12) for the rotating movement of said blades (2) about a longitudinal axis thereof between a first stroke-end position, wherein the blades are arranged spaced apart parallel from one another, and a second stroke-end position, wherein the blades substantially are coplanar to one another with the longitudinal edges in contact,
- a microcontroller (18) for managing said first (6) and second motor (12), characterized in that it also comprises:
- detection means (10, 16) of the supply current of said first and second motor (6, 12) and corresponding control units (8, 14) of the supply current of said first and second motor (6, 12), said detection means (10, 16) and said control circuits (8, 14) being connected with said microcontroller (18),
and in that:
- said first motor (6) and said second motor (12) are provided with internal stroke ends which are associated with said control units (8, 14) to control the supply current to be sent to the first and second motor (6, 12) input,
- said microcontroller (18) is programmed to manage said first and second motor (6, 12) on the basis of what is detected by said detection means (10, 16) of the supply current so as to enable the operation of said first motor (6) only when said second motor (12) is in said first stroke-end position, and to enable the operation of said second motor (12) only when said first motor is in said first stroke-end position.
Description
- The present invention relates to an infrastructure for controlling and moving a blade closure of a pergola or the like.
- So-called "pergolas" are known, which practically consist of rigid support structures generally having parallelepiped shape and involved on the top wall, and sometimes also on the side walls, by movable blade closures. Each closure comprises a plurality of parallel blades, which may be moved both by translating movement perpendicular to the longitudinal axis thereof, to pass from an unfolded or closed condition to a packed or open position, and by rotating motion about the longitudinal axis thereof to be oriented according to the shielding effect which is to be obtained therewith. In particular, in this latter case, they may be simultaneously oriented for an angular range slightly less than 90° in order to pass from a substantially coplanar arrangement for intercepting the light to a substantially parallel arrangement for letting the light pass.
- Pergolas are also known, such as the one described in
AU 2007 237309 - In the present description, translation is used to define the movement which causes the blades to pass from an open configuration (blades unfolded) to a closed configuration (blades packed) and vice versa, while rotation is used to define the movement which causes the blades to be orientated about the longitudinal axis thereof to allow more or less light to pass therebetween.
- Again in known drive systems of the blades of a pergola, there is a need to create coordination between the translating and rotating movements in that the blades may be oriented only when they are unfolded, and i.e. they have taken on an open configuration, while they may not be oriented when they are completely or partly packed, and i.e. they have taken on a closed configuration.
- At the same time, the translation of the blades should be allowed only when they are arranged parallel to one another, while it should be avoided when the blades are oriented differently.
- In known blade movement systems of one pergola, the two separate translating and rotating movements are obtained with separate electrical motors, which are controlled by a control unit through a single board in which separate control units are provided for the two motors.
- The conditioning of the movements of the two motors is obtained with traditional mechanical sensors, which are located at the end positions both of the translating movement of the blades and of the rotating movement thereof.
- For example,
EP 2868833 describes a pergola in which the cover is defined by a plurality of blades and in which both the motor for the translating movement of the blades and the motor for the rotating movement of the blades are managed by a same control unit. Moreover, two position sensors which are conveniently mounted on the support structure of the pergola, and therefore are external to the two motors, are provided for detecting if the blades are coplanar (and therefore in the closed condition) and if the cover is in the open condition (i.e. if the blades are unfolded and spaced apart from one another), respectively. These sensors then generate corresponding signals which are sent to the control unit which is conveniently installed inside an upright of the support structure of the pergola. - To obtain the required coordination in the operation of the two motors, the position sensors are to be connected to the control unit, to which the two motors are also connected, and this requires a series of wire assemblies which may require a laborious installation and even more laborious modifications in the infrequent case in which the position of the control unit is to be moved.
- All these problems are significantly magnified with the current tubular motors, which are provided with internal stroke ends which are more difficult to access to make the electrical connections required with the control unit.
- It is the object of the present invention to eliminate these drawbacks and to propose an infrastructure for controlling and moving the blade closure of a pergola or the like, which reduces the number of wire assemblies required.
- It is another object of the invention to propose an infrastructure which is simple to install and safe and reliable to operate.
- It is another object of the invention to propose an infrastructure which may be obtained and configured in a simple, quick and affordable manner.
- It is another object of the invention to propose an improved and/or alternative infrastructure with respect to traditional ones.
- These objects, both individually and in any combination thereof, and others which will become apparent from the description below are achieved according to the invention, with an infrastructure with the characteristics indicated in
claim 1 and with a pergola according toclaim 14. - The present invention is hereinbelow further clarified in a preferred embodiment thereof, which is described by mere way of non-limiting example, with reference to the accompanying drawings, in which:
-
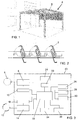
Figure 1 shows a perspective diagrammatical view of a pergola, to which there is applied a blade closure which is controlled and moved with an infrastructure according to the invention, -
Figure 2 shows a detail of the orientation system of the blades of the pergola, -
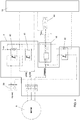
Figure 3 shows the block diagram of the infrastructure according to the invention, and -
Figure 4 shows the electronic diagram of certain details infigure 3 , in greater detail. - As shown in the drawings, the infrastructure according to the invention may be used to control the two motors which perform the translating and rotating movements of a blade closure of a pergola or the like.
- More specifically, with reference to the drawings, the
blades 2 ofpergola 4 are actuated in translation by afirst motor 6 through afirst control unit 8 to which first detection means 10 of the current supplying the motor itself, are associated. - Moreover, the
blades 2 are actuated in rotation about the longitudinal axis thereof, by asecond motor 12 through asecond control unit 14 to which second detection means 16 of the current supplying the motor itself, are associated. - The two
motors respective control units - The two
management units motors microcontroller 18. In greater detail, the detection means 10, 16 of the current which supplies the motor comprise sensors which measure the absorption of current by the motor itself. - In particular, the
control units supply current 39 to be sent to the input of thecorresponding motors - In greater detail, as shown in
fig. 4 for the first motor 6 (but it is also understood that this also applies in corresponding manner to the second motor 12), the electronic circuit of thecontrol unit 8 comprises afirst relay 40, which is associated with the "open" terminal for the rotation of the motor in a first direction, and asecond relay 41, which is associated with the "close" terminal for the rotation of the motor itself in the opposite direction. Preferably, athird safety relay 42 is also provided, associated with the terminal of the common ofmotor 6. - Associated with the terminal of the common of
motor 6, preferably in series with thethird relay 42, issensor 10 which detects the current absorption by the motor itself. In particular, thissensor 10 is galvanically isolated between input and output and furthermore, the output thereof is connected tomicrocontroller 18 by means of anoperational amplifier 44. - The two
management units microcontroller 18 are installed or incorporated in a sameelectronic board 20. Advantageously, such anelectronic board 20 is applied to or incorporated in the control unit for managing the whole infrastructure or pergola. - Associated with the
microcontroller 18 itself is also aradio receiver 24, by means of which controls may be imparted to the microcontroller itself by means of a remote control. - Advantageously, the infrastructure according to the invention also comprises detection sensors of specific atmospheric quantities which are connected to the
microcontroller 18 input in order to automatically affect the operation of the infrastructure. - In greater detail, an
input 26 for an external rain sensor, aninput 28 for an external wind sensor and/or aninput 30 for an external temperature sensor are connected tomicrocontroller 18. - Advantageously, a
memory 32 configured to store therein the position data of themotors microcontroller 18. - Advantageously, a
programming button 34 and a plurality ofcabled control buttons 36 are associated withmicrocontroller 18. -
Microcontroller 18 is configured to act on thecorresponding control units first motor 6 or saidsecond motor 12. - Preferably, enabling the operation of each motor is performed by sending a suitable signal at the common terminal of each motor, while the successive actuation of each motor is performed by sending a suitable signal at the "open" or "close" terminal of the motor itself. Conveniently, the
motors - In particular, it is understood that when said first 6 and
second motor 12 are enabled to operate, they are in a state in which a suitable successive control, which is imparted via radio and is connected byreceiver 12, or is imparted via cable by means of acorresponding button 36, may induce the actuation of the corresponding motor. In a corresponding manner, when said first 6 andsecond motor 12 are disabled to operate, they are in a state in which they cannot be actuated in any manner, not even if a corresponding control should be imparted. - The operation of the infrastructure according to the invention is as follows.
- In a first condition, the
blades 2 are unfolded, and i.e. they are arranged in open configuration (cfr solid lines infig. 2 ) and they are oriented so as to be parallel to one another. - In this configuration, the
first motor 6 is at open stroke end and in such a condition, the correspondingfirst unit 10 is actuated to control the interruption of the supply current to thefirst motor 6. Then, the detection means 10 detect the interruption of the current supply to thefirst motor 6 and send a corresponding signal tomicrocontroller 18 which enables thesecond motor 12 to operate so that a suitable control imparted via radio and collected byreceiver 24 or imparted via wire by means of acorresponding button 36, may actuate the rotating movement of theblades 2 in the desired manner between the two stroke-end positions thereof, which correspond to the substantially parallel arrangement of theblades 2 and to the substantially coplanar arrangement thereof. - In these two positions, corresponding to the respective end strokes of the
second motor 12, thesecond unit 14 is actuated to control the interruption of the supply current to thesecond motor 12. Then, the second detection means 16 detect the interruption of the current supply to thesecond motor 12 and send a corresponding signal tomicrocontroller 18. - In particular, only when
microcontroller 18 receives the interruption signal of the current supply to thesecond motor 12 from the second detection means 16 following the reaching of the stroke-end position corresponding to the parallel arrangement of theblades 2 does the microcontroller itself enable thefirst motor 6 to operate so that when it receives a suitable control, via radio or via cable as seen above, it actuates the translating movement of said blades 2 - which were previously arranged parallel to one another - in the direction of the packing thereof. - In this step, as soon as the
first motor 6 has started the packing manoeuver of theblades 2,microcontroller 18 disables the operation of thesecond motor 12, which therefore can no longer move the blades in the direction of the rotation thereof, not even if a corresponding control should be imparted. - Essentially,
microcontroller 18 is programmed so that: - only the interruption of current to the
first motor 6 following the reaching of the stroke-end position corresponding to the configuration of unfolded blades enables the operation of thesecond motor 12, and - only the interruption of current to the
second motor 12 following the reaching of the stroke-end position corresponding to the arrangement of parallel blades enables the operation of thefirst motor 6. - The infrastructure according to the invention is particularly advantageous with respect to traditional solutions because:
- it does not have any position sensors to be mounted on the support structure of the pergola,
- due to the use of the strokes ends inside the motors, the fact that the management units thereof and of the detection means are mounted on an electronic board associated with the control unit, and also due to the method of coordinating the operation of the two motors by means of specifically programming the microprocessor, all the cable connections required in traditional solutions are significantly reduced, with significant system simplifications both during the step of first installation and in the case of possible movement of the control unit; in particular, in the infrastructure according to the invention there conveniently is a need for one wire assembly alone in order to connect each motor with the corresponding management unit provided on the electronic board installed and/or incorporated in the control unit.
Claims (15)
- An infrastructure for controlling and moving a blade closure (2) of a pergola or the like, said infrastructure comprises:- a first motor (6) for the translating movement of said blades (2) between a first stroke-end position, wherein the blades are unfolded in open configuration, and a second stroke-end position, wherein the blades are packed in closed configuration,- a second motor (12) for the rotating movement of said blades (2) about a longitudinal axis thereof between a first stroke-end position, wherein the blades are arranged spaced apart parallel from one another, and a second stroke-end position, wherein the blades substantially are coplanar to one another with the longitudinal edges in contact,- a microcontroller (18) for managing said first (6) and second motor (12), characterized in that it also comprises:- detection means (10, 16) of the supply current of said first and second motor (6, 12) and corresponding control units (8, 14) of the supply current of said first and second motor (6, 12), said detection means (10, 16) and said control circuits (8, 14) being connected with said microcontroller (18),and in that:- said first motor (6) and said second motor (12) are provided with internal stroke ends which are associated with said control units (8, 14) to control the supply current to be sent to the first and second motor (6, 12) input,- said microcontroller (18) is programmed to manage said first and second motor (6, 12) on the basis of what is detected by said detection means (10, 16) of the supply current so as to enable the operation of said first motor (6) only when said second motor (12) is in said first stroke-end position, and to enable the operation of said second motor (12) only when said first motor is in said first stroke-end position.
- An infrastructure according to claim 1, characterized in that said first and second motors (6, 12) are provided with internal mechanical stroke ends.
- An infrastructure according to claim 1, characterized in that said first and second motors (6, 12) are provided with internal electronic stroke ends.
- An infrastructure according to one or more of the preceding claims, characterized in that said microcontroller (18) is programmed to manage said first and second motors (6, 12) through said control units (8, 14).
- An infrastructure according to one or more of the preceding claims, characterized in that said microcontroller (18), said control units (8, 14) of the supply current to be sent to said motors (6, 12) and said detection means (10, 16) of the supply current of said motors (6, 12) are installed and/or incorporated in a same electronic board (20).
- An infrastructure according to one or more of the preceding claims, characterized in that said motors (6, 12) are electrically connected only with said control units (8, 14) provided in said electronic board (20).
- An infrastructure according to one or more of the preceding claims, characterized in that said control units (8, 14) comprise electronic circuits for controlling and/or interrupting the supply current to be provided to the respective motor (6, 12) input.
- An infrastructure according to one or more of the preceding claims, characterized in that said stroke ends inside the motors (6, 12) are associated with said control units (8, 14) to control the interruption of current to be sent to the motor input when said motor (6) reaches a stroke-end position.
- An infrastructure according to one or more of the preceding claims, characterized in that said microcontroller (18) is connected to a radio control receiver (24) of said first and second motors (6, 12).
- An infrastructure according to one or more of the preceding claims, characterized in that sensors (26, 28, 30) of external meteorological quantities are connected to said microcontroller (18).
- An infrastructure according to the preceding claim, characterized in that said sensors of external meteorological quantities comprise an external sensor of rain (26), and/or of wind (28) and/or of temperature (30).
- An infrastructure according to one or more of the preceding claims, characterized in that wire control buttons (36) of said first and second motors (6, 12) are connected to said microcontroller (18).
- An infrastructure according to one or more of the preceding claims, characterized in that a memory (32) for storing the position data of said first and second motors (6, 12) and remote control codes is connected to said microcontroller (18).
- A pergola comprising a blade closure which is moved and controlled with an infrastructure according to one or more of the preceding claims.
- A pergola according to the preceding claim, characterized in that it does not comprise any sensors for detecting the position of said blades (2).
Applications Claiming Priority (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| ITUB2015A009232A ITUB20159232A1 (en) | 2015-12-29 | 2015-12-29 | Control and command device for the movement motors of a lamellar pergola closure. |
Publications (2)
| Publication Number | Publication Date |
|---|---|
| EP3196379A1 true EP3196379A1 (en) | 2017-07-26 |
| EP3196379B1 EP3196379B1 (en) | 2018-05-09 |
Family
ID=55697331
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| EP16207180.7A Active EP3196379B1 (en) | 2015-12-29 | 2016-12-28 | Infrastructure for controlling and moving a blade closure of a pergola |
Country Status (5)
| Country | Link |
|---|---|
| EP (1) | EP3196379B1 (en) |
| ES (1) | ES2681520T3 (en) |
| IT (1) | ITUB20159232A1 (en) |
| PT (1) | PT3196379T (en) |
| TR (1) | TR201809512T4 (en) |
Cited By (4)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| EP3604705A1 (en) * | 2018-07-30 | 2020-02-05 | WAREMA Renkhoff SE | Device for limiting the displacement of drives |
| EP3663480A1 (en) * | 2018-12-06 | 2020-06-10 | Weinor GmbH & Co. KG | Slatted roof with drop protection |
| IT202100019322A1 (en) * | 2021-07-21 | 2023-01-21 | Teleco Automation Srl | Improved Handling Apparatus. |
| IT202200004634A1 (en) | 2022-03-10 | 2023-09-10 | Tender Srl | DRIVE DEVICE FOR A PERGOLA |
Citations (3)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| AU2007237309A1 (en) | 2006-12-05 | 2008-06-19 | Stratco (Australia) Pty Limited | An improved louvred roofing system and components |
| EP2079058A2 (en) * | 2007-12-28 | 2009-07-15 | Teleco Automation S.R.L. | Multiple user device for radio-commanded access control |
| EP2868833A1 (en) | 2013-10-31 | 2015-05-06 | Soliso Europe | Slat panel for lightweight construction such as a pergola, garden shelter or the like and lightweight structure including such a panel |
-
2015
- 2015-12-29 IT ITUB2015A009232A patent/ITUB20159232A1/en unknown
-
2016
- 2016-12-28 PT PT162071807T patent/PT3196379T/en unknown
- 2016-12-28 ES ES16207180.7T patent/ES2681520T3/en active Active
- 2016-12-28 EP EP16207180.7A patent/EP3196379B1/en active Active
-
2017
- 2017-12-28 TR TR2018/09512T patent/TR201809512T4/en unknown
Patent Citations (3)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| AU2007237309A1 (en) | 2006-12-05 | 2008-06-19 | Stratco (Australia) Pty Limited | An improved louvred roofing system and components |
| EP2079058A2 (en) * | 2007-12-28 | 2009-07-15 | Teleco Automation S.R.L. | Multiple user device for radio-commanded access control |
| EP2868833A1 (en) | 2013-10-31 | 2015-05-06 | Soliso Europe | Slat panel for lightweight construction such as a pergola, garden shelter or the like and lightweight structure including such a panel |
Cited By (6)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| EP3604705A1 (en) * | 2018-07-30 | 2020-02-05 | WAREMA Renkhoff SE | Device for limiting the displacement of drives |
| EP3604705B1 (en) | 2018-07-30 | 2022-02-16 | WAREMA Renkhoff SE | Device for limiting the displacement of drives |
| EP3663480A1 (en) * | 2018-12-06 | 2020-06-10 | Weinor GmbH & Co. KG | Slatted roof with drop protection |
| IT202100019322A1 (en) * | 2021-07-21 | 2023-01-21 | Teleco Automation Srl | Improved Handling Apparatus. |
| WO2023002428A1 (en) * | 2021-07-21 | 2023-01-26 | Teleco Automation S.R.L. | Movement apparatus for a covering and/or closing installation |
| IT202200004634A1 (en) | 2022-03-10 | 2023-09-10 | Tender Srl | DRIVE DEVICE FOR A PERGOLA |
Also Published As
| Publication number | Publication date |
|---|---|
| TR201809512T4 (en) | 2018-07-23 |
| EP3196379B1 (en) | 2018-05-09 |
| ES2681520T3 (en) | 2018-09-13 |
| PT3196379T (en) | 2018-07-23 |
| ITUB20159232A1 (en) | 2017-06-29 |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| EP3196379B1 (en) | Infrastructure for controlling and moving a blade closure of a pergola | |
| US6714107B2 (en) | Remote operated circuit breaker panel | |
| CA2134682C (en) | Motor driven step switch | |
| CA2826618C (en) | Architectural opening coverings and methods | |
| EP2850628B1 (en) | Hinged electronic safety switch | |
| US20200251297A1 (en) | Bus plug including remotely operated circuit breaker and electrical system including the same | |
| KR101346056B1 (en) | Apparatus and method for controlling environment of greenhouse | |
| WO2004015235A1 (en) | Control device with interchangeable electronic card for rolling elements such as roller blinds, roller shutters, awnings and so forth | |
| US11387715B2 (en) | Switching device for switching an electric motor | |
| KR100981643B1 (en) | Humidity Control Device of Switchgear | |
| US9331608B2 (en) | Actuator control circuit | |
| EP3770358B1 (en) | Device for moving and controlling at least one covering and/or closing element | |
| EP4374023B1 (en) | Handling apparatus for moving a covering and/or closing element of a covering and/or closing installation | |
| US12166443B2 (en) | Switching device, electrical drive and method for setting up a switching device | |
| US8264185B2 (en) | Apparatus for rotating shutter's axis | |
| KR20200043201A (en) | Window opening and shutting apparatus for outdoor unit of air conditioner | |
| EP2781847B1 (en) | A building ventilation system with connection detection | |
| WO2022263953A1 (en) | Rotary electric machine with programmable interface | |
| FI79205B (en) | ELLINJEAVBRYTARE. | |
| US10050570B2 (en) | Motor control circuit and method of use | |
| JP6388503B2 (en) | Switchgear control system | |
| EP1617226A2 (en) | Integrated system for the control of protection devices against environmental influences | |
| DE102004057824A1 (en) | Electronic pressure switch comprises an electronic control circuit with a printed circuit board with a pressure sensor and actuator | |
| WO2005088061A1 (en) | Venetian blind with mechanical stop | |
| CN102211515A (en) | Method for adjusting a soft top and motor vehicle |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| PUAI | Public reference made under article 153(3) epc to a published international application that has entered the european phase |
Free format text: ORIGINAL CODE: 0009012 |
|
| AK | Designated contracting states |
Kind code of ref document: A1 Designated state(s): AL AT BE BG CH CY CZ DE DK EE ES FI FR GB GR HR HU IE IS IT LI LT LU LV MC MK MT NL NO PL PT RO RS SE SI SK SM TR |
|
| AX | Request for extension of the european patent |
Extension state: BA ME |
|
| GRAP | Despatch of communication of intention to grant a patent |
Free format text: ORIGINAL CODE: EPIDOSNIGR1 |
|
| 17P | Request for examination filed |
Effective date: 20171106 |
|
| RBV | Designated contracting states (corrected) |
Designated state(s): AL AT BE BG CH CY CZ DE DK EE ES FI FR GB GR HR HU IE IS IT LI LT LU LV MC MK MT NL NO PL PT RO RS SE SI SK SM TR |
|
| INTG | Intention to grant announced |
Effective date: 20171208 |
|
| GRAS | Grant fee paid |
Free format text: ORIGINAL CODE: EPIDOSNIGR3 |
|
| GRAA | (expected) grant |
Free format text: ORIGINAL CODE: 0009210 |
|
| AK | Designated contracting states |
Kind code of ref document: B1 Designated state(s): AL AT BE BG CH CY CZ DE DK EE ES FI FR GB GR HR HU IE IS IT LI LT LU LV MC MK MT NL NO PL PT RO RS SE SI SK SM TR |
|
| REG | Reference to a national code |
Ref country code: GB Ref legal event code: FG4D |
|
| REG | Reference to a national code |
Ref country code: CH Ref legal event code: EP Ref country code: AT Ref legal event code: REF Ref document number: 997688 Country of ref document: AT Kind code of ref document: T Effective date: 20180515 |
|
| REG | Reference to a national code |
Ref country code: IE Ref legal event code: FG4D |
|
| REG | Reference to a national code |
Ref country code: DE Ref legal event code: R096 Ref document number: 602016002998 Country of ref document: DE |
|
| REG | Reference to a national code |
Ref country code: PT Ref legal event code: SC4A Ref document number: 3196379 Country of ref document: PT Date of ref document: 20180723 Kind code of ref document: T Free format text: AVAILABILITY OF NATIONAL TRANSLATION Effective date: 20180713 |
|
| REG | Reference to a national code |
Ref country code: NL Ref legal event code: FP |
|
| REG | Reference to a national code |
Ref country code: ES Ref legal event code: FG2A Ref document number: 2681520 Country of ref document: ES Kind code of ref document: T3 Effective date: 20180913 |
|
| REG | Reference to a national code |
Ref country code: LT Ref legal event code: MG4D |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: LT Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20180509 Ref country code: FI Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20180509 Ref country code: BG Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20180809 Ref country code: SE Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20180509 Ref country code: NO Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20180809 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: GR Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20180810 Ref country code: RS Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20180509 Ref country code: HR Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20180509 Ref country code: LV Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20180509 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: RO Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20180509 Ref country code: CZ Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20180509 Ref country code: SK Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20180509 Ref country code: PL Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20180509 Ref country code: EE Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20180509 Ref country code: DK Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20180509 |
|
| REG | Reference to a national code |
Ref country code: DE Ref legal event code: R097 Ref document number: 602016002998 Country of ref document: DE |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: SM Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20180509 |
|
| PLBE | No opposition filed within time limit |
Free format text: ORIGINAL CODE: 0009261 |
|
| STAA | Information on the status of an ep patent application or granted ep patent |
Free format text: STATUS: NO OPPOSITION FILED WITHIN TIME LIMIT |
|
| 26N | No opposition filed |
Effective date: 20190212 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: LU Free format text: LAPSE BECAUSE OF NON-PAYMENT OF DUE FEES Effective date: 20181228 Ref country code: MC Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20180509 |
|
| REG | Reference to a national code |
Ref country code: IE Ref legal event code: MM4A |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: IE Free format text: LAPSE BECAUSE OF NON-PAYMENT OF DUE FEES Effective date: 20181228 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: AL Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20180509 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: MT Free format text: LAPSE BECAUSE OF NON-PAYMENT OF DUE FEES Effective date: 20181228 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: MK Free format text: LAPSE BECAUSE OF NON-PAYMENT OF DUE FEES Effective date: 20180509 Ref country code: HU Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT; INVALID AB INITIO Effective date: 20161228 Ref country code: CY Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20180509 |
|
| REG | Reference to a national code |
Ref country code: AT Ref legal event code: UEP Ref document number: 997688 Country of ref document: AT Kind code of ref document: T Effective date: 20180509 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: IS Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20180909 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: SI Free format text: LAPSE BECAUSE OF NON-PAYMENT OF DUE FEES Effective date: 20181228 |
|
| GBPC | Gb: european patent ceased through non-payment of renewal fee |
Effective date: 20201228 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: GB Free format text: LAPSE BECAUSE OF NON-PAYMENT OF DUE FEES Effective date: 20201228 |
|
| PGFP | Annual fee paid to national office [announced via postgrant information from national office to epo] |
Ref country code: PT Payment date: 20251117 Year of fee payment: 10 |
|
| REG | Reference to a national code |
Ref country code: CH Ref legal event code: U11 Free format text: ST27 STATUS EVENT CODE: U-0-0-U10-U11 (AS PROVIDED BY THE NATIONAL OFFICE) Effective date: 20260101 |
|
| PGFP | Annual fee paid to national office [announced via postgrant information from national office to epo] |
Ref country code: DE Payment date: 20251127 Year of fee payment: 10 |
|
| PGFP | Annual fee paid to national office [announced via postgrant information from national office to epo] |
Ref country code: AT Payment date: 20251127 Year of fee payment: 10 |
|
| PGFP | Annual fee paid to national office [announced via postgrant information from national office to epo] |
Ref country code: IT Payment date: 20251117 Year of fee payment: 10 |
|
| PGFP | Annual fee paid to national office [announced via postgrant information from national office to epo] |
Ref country code: FR Payment date: 20251117 Year of fee payment: 10 Ref country code: NL Payment date: 20251127 Year of fee payment: 10 |
|
| PGFP | Annual fee paid to national office [announced via postgrant information from national office to epo] |
Ref country code: BE Payment date: 20251127 Year of fee payment: 10 Ref country code: TR Payment date: 20251118 Year of fee payment: 10 |
|
| PGFP | Annual fee paid to national office [announced via postgrant information from national office to epo] |
Ref country code: ES Payment date: 20260113 Year of fee payment: 10 |
|
| PGFP | Annual fee paid to national office [announced via postgrant information from national office to epo] |
Ref country code: CH Payment date: 20260101 Year of fee payment: 10 |