WO2014017418A1 - 船舶監視装置 - Google Patents
船舶監視装置 Download PDFInfo
- Publication number
- WO2014017418A1 WO2014017418A1 PCT/JP2013/069740 JP2013069740W WO2014017418A1 WO 2014017418 A1 WO2014017418 A1 WO 2014017418A1 JP 2013069740 W JP2013069740 W JP 2013069740W WO 2014017418 A1 WO2014017418 A1 WO 2014017418A1
- Authority
- WO
- WIPO (PCT)
- Prior art keywords
- information
- ship
- data
- fender
- packet data
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Ceased
Links
Images




Classifications
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B63—SHIPS OR OTHER WATERBORNE VESSELS; RELATED EQUIPMENT
- B63B—SHIPS OR OTHER WATERBORNE VESSELS; EQUIPMENT FOR SHIPPING
- B63B21/00—Tying-up; Shifting, towing, or pushing equipment; Anchoring
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B63—SHIPS OR OTHER WATERBORNE VESSELS; RELATED EQUIPMENT
- B63B—SHIPS OR OTHER WATERBORNE VESSELS; EQUIPMENT FOR SHIPPING
- B63B43/00—Improving safety of vessels, e.g. damage control, not otherwise provided for
- B63B43/18—Improving safety of vessels, e.g. damage control, not otherwise provided for preventing collision or grounding; reducing collision damage
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B63—SHIPS OR OTHER WATERBORNE VESSELS; RELATED EQUIPMENT
- B63B—SHIPS OR OTHER WATERBORNE VESSELS; EQUIPMENT FOR SHIPPING
- B63B49/00—Arrangements of nautical instruments or navigational aids
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B63—SHIPS OR OTHER WATERBORNE VESSELS; RELATED EQUIPMENT
- B63B—SHIPS OR OTHER WATERBORNE VESSELS; EQUIPMENT FOR SHIPPING
- B63B59/00—Hull protection specially adapted for vessels; Cleaning devices specially adapted for vessels
- B63B59/02—Fenders integral with waterborne vessels or specially adapted therefor, e.g. fenders forming part of the hull or incorporated in the hull; Rubbing-strakes
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B63—SHIPS OR OTHER WATERBORNE VESSELS; RELATED EQUIPMENT
- B63B—SHIPS OR OTHER WATERBORNE VESSELS; EQUIPMENT FOR SHIPPING
- B63B79/00—Monitoring properties or operating parameters of vessels in operation
- B63B79/10—Monitoring properties or operating parameters of vessels in operation using sensors, e.g. pressure sensors, strain gauges or accelerometers
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B63—SHIPS OR OTHER WATERBORNE VESSELS; RELATED EQUIPMENT
- B63B—SHIPS OR OTHER WATERBORNE VESSELS; EQUIPMENT FOR SHIPPING
- B63B21/00—Tying-up; Shifting, towing, or pushing equipment; Anchoring
- B63B2021/003—Mooring or anchoring equipment, not otherwise provided for
- B63B2021/009—Drift monitors
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B63—SHIPS OR OTHER WATERBORNE VESSELS; RELATED EQUIPMENT
- B63B—SHIPS OR OTHER WATERBORNE VESSELS; EQUIPMENT FOR SHIPPING
- B63B2203/00—Communication means
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B63—SHIPS OR OTHER WATERBORNE VESSELS; RELATED EQUIPMENT
- B63B—SHIPS OR OTHER WATERBORNE VESSELS; EQUIPMENT FOR SHIPPING
- B63B2213/00—Navigational aids and use thereof, not otherwise provided for in this class
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B63—SHIPS OR OTHER WATERBORNE VESSELS; RELATED EQUIPMENT
- B63B—SHIPS OR OTHER WATERBORNE VESSELS; EQUIPMENT FOR SHIPPING
- B63B2213/00—Navigational aids and use thereof, not otherwise provided for in this class
- B63B2213/02—Navigational aids and use thereof, not otherwise provided for in this class using satellite radio beacon positioning systems, e.g. the Global Positioning System GPS
-
- G—PHYSICS
- G01—MEASURING; TESTING
- G01C—MEASURING DISTANCES, LEVELS OR BEARINGS; SURVEYING; NAVIGATION; GYROSCOPIC INSTRUMENTS; PHOTOGRAMMETRY OR VIDEOGRAMMETRY
- G01C21/00—Navigation; Navigational instruments not provided for in groups G01C1/00 - G01C19/00
- G01C21/20—Instruments for performing navigational calculations
- G01C21/203—Instruments for performing navigational calculations specially adapted for water-borne vessels
Definitions
- the present invention provides the operator with information on the positional relationship between the two ships and the state of the fender when the two ships are in contact with each other and when the two ships are moored with each other.
- the present invention relates to a ship monitoring device.
- Patent Document 1 WO2008 / 053887
- the marine vessel maneuvering and ship mooring support method and the system disclosed in Patent Document 1 can easily grasp the positional relationship of each ship and the state of the fender when performing ship berthing and ship mooring.
- the information on the positional relationship between the two ships and the information on the fender are displayed as possible.
- Patent Document 2 Japanese Patent Laid-Open No. 2007-4428
- Patent Document 3 pneumatic fenders disclosed in Japanese Patent Laid-Open No. 2010-175298
- Patent Document 4 An air pressure monitoring device and its centralized management system, and a fender and its management system disclosed in WO99 / 20845 (Patent Document 4) are known.
- the other ship target display device disclosed in Patent Document 2 is an apparatus that displays the position and detailed information of almost all ships existing in a predetermined area around the own ship in an easy-to-understand manner for the operator.
- the air pressure monitoring device for pneumatic fenders and its centralized management system disclosed in Patent Document 3 are provided with a plurality of pressure sensors on the pneumatic fenders, and each pressure sensor sends a pneumatic detection signal at a predetermined interval. In order to continuously transmit each other, the transmission is repeated in order so that the air pressure of the pneumatic fender can be constantly monitored.
- the fender and the management system disclosed in Patent Document 4 access information storage means of a transponder provided in each of a plurality of fenders by a terminal device, and read information stored in the information storage means The fenders are managed by displaying the read information.
- Patent Document 1 When two ships are in contact with each other and when two ships are moored with each other, information on the positional relationship between the two ships and fenders that serve as cushioning materials during the connection between the two ships It is very important for the operator to know information such as the internal air pressure state. A system that makes it easy to connect two ships in this way is disclosed in detail in Patent Document 1.
- the inventors of the present invention use a specific low-power radio device, but information transmitted from each fender to the main unit, the main unit of the first ship, and the main unit of the second ship A device for identifying the information exchanged with the device and a device for identifying the communication information type are required.
- An object of the present invention is to provide a ship monitoring apparatus that can identify fender information communication and information communication between two ships and can easily identify the type of communication information.
- the present invention displays the position of the ship and the position of the ship and the position of the ship as a result of animation based on the information of the ship and the information of the ship as a target.
- a display unit that displays the contact state of the target ship, and is provided between the ship and the target ship when the ship is in contact with the ship and the target ship.
- a detection information communication unit including a specific low-power radio that receives, as packet data, internal air pressure information transmitted from specific low-power radios provided on a plurality of fenders, and the detection information communication unit
- the own ship information transmitter having a specific low-power radio that transmits the own ship information including one or more kinds of information to the target ship as packet data with the detection information included in the packet data received by
- the means arranges one type of own ship information between two consecutive start control codes and two consecutive end control codes, and between the own ship information and the start control code and between the end control code, Proposed is a ship monitoring device that arranges type information representing an information type of the own ship information between the own ship information and transmits the information as packet data of the own ship information.
- the ship monitoring device of the present invention arranges one kind of ship information between two start control codes that are continuous by the ship information transmitting means and two end control codes that are continuous, and the ship information and the start. Since the type information representing the information type of the own ship information is arranged between the control code and between the end control code and the own ship information and transmitted as packet data of the own ship information, the own ship Information and detection information can be easily distinguished, and the information type sent as own ship information can be easily identified.
- the block diagram which shows the ship monitoring apparatus in one Embodiment of this invention The figure which shows the state of the marine vessel target ship and own ship on the sea The figure explaining the communication of the ship monitoring apparatus in one Embodiment of this invention, and the communication between a ship monitoring apparatus and a fender
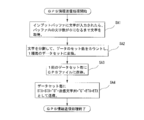
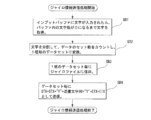
- the flowchart explaining the GPS information transmission process in one Embodiment of this invention The flowchart explaining the gyro information transmission process in one Embodiment of this invention
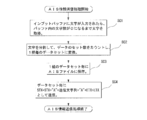
- the flowchart explaining the AIS information transmission process in one Embodiment of this invention The flowchart explaining the fender information transmission process in one Embodiment of this invention
- FIG. 1 is a block diagram showing a ship monitoring apparatus according to an embodiment of the present invention.
- reference numeral 1 denotes a ship monitoring device, which includes a computer 11, a fender communication unit 12, an AIS communication unit 13, a GNSS communication unit 14, a gyro communication unit 15, a wireless communication unit 16, a display unit 17, and an operation unit 18.
- This ship monitoring apparatus 1 is installed in the steering room of a ship.
- the computer 11 includes a known computer main body, keyboard, mouse, storage device, display device, and the like.
- a ship monitoring program is stored in advance in the storage device of the computer 11, and the computer 11 operates according to the ship monitoring program. Further, the computer 11 stores the information acquired from each of the fender communication unit 12, the AIS communication unit 13, the GNSS communication unit 14, the gyro communication unit 15, and the wireless communication unit 16 in a storage device included in the computer 11, and acquires these. Based on the plurality of information, the position information of the own ship and the other ship serving as the target ship for ships is animated on the display unit 17 in real time, and the internal air pressure information of each fender (fender) is displayed in real time. .
- the computer 11 displays a plurality of acquired information on the display unit 17 and executes an operation instruction input from the operation unit 18.
- the computer 11 transmits the acquired information related to the ship and the information on the fender to the other ship (hereinafter referred to as a ship to be touched) via the wireless communication unit 16 and wirelessly.
- the ship information of the fishery target ship is received via the communication unit 16, and the animation display is performed based on the received information of the fishery target ship.
- the fender communication unit 12 performs communication between the computer 11 and a transmitter provided in the fender, acquires information such as air pressure and temperature inside the fender, and outputs the acquired information to the computer 11 as digital data.
- a ship is equipped with four fenders for the reception. These fenders are provided with a transmitter including a sensor, the air pressure and temperature inside the fender are detected by the sensor, and the detection result is transmitted by the transmitter. Further, the transmitter transmits the serial number of the sensor in addition to the air pressure and temperature information of the detection result.
- a known specific low-power radio is used for the fender communication unit 12 and the fender transmitter, and the detection result is transmitted as packet data.
- the serial number of the sensor, the air pressure and temperature information of the detection result, etc. are collectively sent as transmission data by the fender transponder, and the start control code “STX” is added before this transmission data and the transmission data The end control code “ETX” is added later, and packet data in the format of “STX + transmission data + ETX” is transmitted.
- An AIS (Automatic Identification System) communication unit 13 is connected to a well-known AIS apparatus 31 and is received by the AIS apparatus 31, such as an identification code, ship name, position, course, speed, destination, etc. Information is output to the computer 11, and AIS information such as the ship's identification code, ship name, position, course, speed, destination, etc. is transmitted to other ships as digital data, and the AIS information of the ship is also transmitted. Output to the computer 11.
- AIS Automatic Identification System
- a GNSS (Global Navigation Satellite System) communication unit 14 is a GPS (Global Navigation Satellite System) communication unit.
- Positioning System Global Positioning System
- the gyro communication unit 15 is connected to a known gyro measurement device 33 having a known gyroscope, detects the angle and angular velocity of the ship, and outputs the detected information to the computer 11 as digital data.
- the wireless communication unit 16 includes a well-known specific low-power wireless device, and transmits information related to the ship as packet data using radio waves of a predetermined frequency based on instructions from the computer 11 and also receives a contact target transmitted from the ship target ship. Information on the ship is received, the received information is sequentially stored in the reception data buffer, and the reception data is output to the computer 11 as digital data in the order of storage.
- the information about the ship includes GPS information, gyro information, AIS information, fender information, and the like.
- the GPS information includes information on the installation position of the GPS receiving antenna, information on the position (latitude and longitude) of the ship, and speed (speed).
- Speed direction information includes information on the ship's angle and angular velocity
- AIS information includes ship shape (length, width) information
- Fender information includes information on fender shape, information on internal air pressure and internal temperature of each fender, etc. .
- the information regarding the other ship transmitted from the other ship is the same information as described above, and the information is shared between the own ship and the other ship serving as the berthing target ship via the wireless communication unit 16.
- the position information of the own ship and the other ship can be accurately displayed on the display unit 17 in real time and the change in the air pressure in the fender can be accurately displayed on the display unit 17 in real time.
- the computer 11 transmits each type of information in real time via the wireless communication unit 16, and transmits each type of information as packet data. That is, the computer 11 transmits information as packet data for each of GPS information, gyro information, AIS information, and fender information via the wireless communication unit 16.
- the computer 11 adds two start control codes “STX” before the transmission data and two end control codes “ETX” after the transmission data via the wireless communication unit 16, and further starts control.
- the character “G” indicating the information type indicates that the transmission data is GPS information.
- the character ““ Y ”” indicating the information type indicates that the transmission data is gyro information
- the character ““ A ”” indicating the information type indicates that the transmission data is AIS information
- the information type is The character “F” represents that the transmission data is fender information.
- the computer 11 while the computer 11 is transmitting a set of transmission data, the computer 11 does not start transmission of other transmission data until the transmission of the transmission data is completed. Thereby, data can be received without interruption.
- the display unit 17 includes a known display such as a liquid crystal display, and displays images and characters based on information sent from the computer 11.
- the operation unit 18 includes a touch panel, a mouse, and a keyboard that are mounted on the display unit 17, and these touch panel, mouse, and keyboard are connected to the computer 11, and each of the operator's operation instructions and input information is digital data. To output to the computer 11.
- the ship monitoring apparatus when the own ship SP1 is in contact with the marching target ship SP2 anchored on the ocean, the radio between the own ship SP1 and the marching target ship SP2 is used. Information exchange by communication will be described.
- the ship monitoring device 1 equivalent to the ship monitoring device 1 installed in the own ship SP1 is installed in the marching target vessel SP2.
- the own ship SP1 is equipped with four fenders 2A to 2D on the left side of the ship, and the fenders 2A to 2D are provided with transmitters 3A to 3D.
- the computer 11 performs GPS information transmission processing, gyro information transmission processing, AIS information transmission processing, and fender information transmission processing when transmitting information, and performs information reception processing when receiving information.
- the computer 11 When performing GPS information transmission processing, as shown in FIG. 4, when the character string of the GPS information received by the GNSS communication unit 14 is input to the input buffer, the computer 11 receives characters until the number of characters in the input buffer becomes zero. Is acquired (SA1). Next, the acquired character string is divided, the number of data sets is counted, and converted into data sets for each set (SA2). Further, each data set is stored in a GPS file (SA3), and packet data “STX + STX +“ G ”+ transmission data +“ G ”+ ETX + ETX” is created and transmitted for each data set ( SA4).
- the computer 11 When performing the gyro information transmission process, as shown in FIG. 5, when the gyro information character string received by the gyro communication unit 15 is input to the input buffer, the computer 11 receives characters until the number of characters in the input buffer becomes zero. Is acquired (SB1). Next, the acquired character string is divided, the number of data sets is counted, and converted into data sets for each set (SB2). Further, each data set is stored in a gyro file (SB3), and packet data “STX + STX +“ Y ”+ transmission data +“ Y ”+ ETX + ETX” is created and transmitted for each data set ( SB4).
- the computer 11 When performing the AIS information transmission process, as shown in FIG. 6, when the AIS information character string received by the AIS communication unit 13 is input to the input buffer, the computer 11 receives characters until the number of characters in the input buffer becomes zero. Is acquired (SC1). Next, the acquired character string is divided, the number of data sets is counted, and converted into data sets for each set (SC2). Further, each data set is stored in an AIS file (SC3), and packet data “STX + STX +“ A ”+ transmission data +“ A ”+ ETX + ETX” is created and transmitted for each data set ( SC4).
- the computer 11 When performing the fender information transmission process, as shown in FIG. 7, when the fender information character string received by the fender communication unit 12 is input to the input buffer, the computer 11 receives characters until the number of characters in the input buffer becomes zero. Is acquired (SD1). Next, the acquired character string is divided, the number of data sets is counted, and converted into data sets for each set (SD2). Further, each set of data is saved in a fender file (SD3), and packet data “STX + STX +“ F ”+ transmission data +“ F ”+ ETX + ETX” is created and transmitted for each data set ( SD4).
- the computer 11 when performing the information reception process, sequentially stores the received data input from the wireless communication unit 16 in the data buffer, analyzes the received data stored in the data buffer in order from the top, and receives the received data.
- the data character string in the packet data corresponds to the information type GPS buffer, gyro buffer, AIS buffer, fender It stores in the buffer and acquires GPS information, gyro information, AIS information, and fender information.
- the computer 11 determines whether or not the GPS information of the packet data “STX + STX +“ G ”+ transmission data +“ G ”+ ETX + ETX” exists in the reception data stored in the data buffer (SE1).
- GPS information exists, only the transmission data in the GPS information is moved and stored in the GPS buffer (SE2), and the GPS information is obtained (SE3).
- gyro information of packet data “STX + STX +“ Y ”+ transmission data +“ Y ”+ ETX + ETX” exists in the reception data stored in the data buffer. If there is gyro information, only the transmission data in the gyro information is moved and stored in the gyro buffer (SE5), and the gyro information is acquired (SE6).
- the AIS information of the packet data “STX + STX +“ A ”+ transmission data +“ A ”+ ETX + ETX” exists in the reception data stored in the data buffer. If there is AIS information, only the transmission data in the AIS information is moved and stored in the AIS buffer (SE8), and the AIS information is obtained (SE9).
- the fender information of the packet data “STX + STX +“ F ”+ transmission data +“ F ”+ ETX + ETX” exists in the reception data stored in the data buffer. If fender information exists, only the transmission data in the fender information is moved and stored in the fender buffer (SE11), and the fender information is acquired (SE12). Thereafter, the processing of SE1 to SE12 is repeated while the reception processing is being performed.
- one type of ship information is arranged as transmission data between two consecutive start control codes “STX” and two consecutive end control codes “ETX”, and the transmission data Type information “G”, “Y”, “A” indicating the information type of the transmission data between the start control code “STX” and between the end control code “ETX” and the transmission data.
- ”And“ F ” are arranged and transmitted as packet data of transmission data, so that the own ship information and the fender detection information can be easily distinguished and the information sent as the own ship information Can be easily identified.
- the position of the ship and the ship to be nailed can be displayed in an animation based on the latest position information of the ship to be nailed, accurate information can be displayed in real time. Furthermore, information communication between fenders and information communication between two ships can be identified, and the communication information type can also be easily identified.
- SYMBOLS 1 ... Ship monitoring apparatus, 11 ... Computer, 12 ... Fender communication part, 13 ... AIS communication part, 14 ... GNSS communication part, 15 ... Gyro communication part, 16 ... Wireless communication part, 17 ... Display part, 18 ... Operation part, 2A-2D ... Fender, 3A-3D ... Transmitter, 31 ... AIS device, 32 ... GNSS device, 33 ... Gyro measuring device, SP1 ... Ship, SP2 ... Ship target ship.
Landscapes
- Engineering & Computer Science (AREA)
- Combustion & Propulsion (AREA)
- Mechanical Engineering (AREA)
- Ocean & Marine Engineering (AREA)
- Chemical & Material Sciences (AREA)
- Radar, Positioning & Navigation (AREA)
- Remote Sensing (AREA)
- Public Health (AREA)
- Health & Medical Sciences (AREA)
- Automation & Control Theory (AREA)
- Physics & Mathematics (AREA)
- General Physics & Mathematics (AREA)
- Traffic Control Systems (AREA)
- Navigation (AREA)
Description
Positioning System:全地球測位システム)受信機を有する周知のGNSS装置32に接続され、周知のようにGNSS装置32によって複数の航法衛星から送信された電波を受信して自船舶の位置情報、速度情報、姿勢情報などの情報を取得し、これらの情報をデジタルデータでコンピュータ11に出力する。
Claims (2)
- 洋上を航行する自船舶の情報と接舷目標船舶の情報に基づき自船舶の位置と接舷目標船舶の位置をアニメーション表示することにより自船舶と接舷目標船舶の接舷状態を表示する表示部を備えると共に、
自船舶に設けられて自船舶と接舷目標船舶との接舷時に自船舶と接舷目標船舶との間に配置されて緩衝材となる複数の防舷材に設けられた特定小電力無線機から送信される内部空気圧情報を検知情報としてパケットデータで受信する特定小電力無線機を含む検知情報通信部と、
前記検知情報通信部によって受信されたパケットデータに含まれる検知情報を1つの種類として1種類以上の情報を含む自船舶情報を接舷目標船舶にパケットデータで送信する特定小電力無線機を有する自船舶情報送信手段とを備え、
前記検知情報通信部によって受信された1つのパケットデータは、開始制御コードと終了制御コードとの間に前記検知情報が配置された形式をなす船舶監視装置において、
前記自船舶情報送信手段は、連続する2つの開始制御コードと連続する2つの終了制御コードとの間に1種類の自船舶情報を配置すると共に該自船舶情報と前記開始制御コードとの間及び前記終了制御コードと該自船舶情報との間のそれぞれに該自船舶情報の情報種別を表す種別情報を配置して前記自船舶情報のパケットデータとして送信する
ことを特徴とする船舶監視装置。 - 前記自船舶情報送信手段は、1種類の自船舶情報の前記開始制御コードを送信した後、該自船舶情報の送信終了を示す終了制御コードを送信するまで、他の情報の送信を行わない
ことを特徴とする請求項1に記載の船舶監視装置。
Priority Applications (6)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| KR1020147034488A KR101579172B1 (ko) | 2012-07-23 | 2013-07-22 | 선박 감시 장치 |
| NO13823802A NO2876033T3 (ja) | 2012-07-23 | 2013-07-22 | |
| EP13823802.7A EP2876033B1 (en) | 2012-07-23 | 2013-07-22 | Ship monitoring device |
| US14/406,646 US9422040B2 (en) | 2012-07-23 | 2013-07-22 | Ship monitoring device |
| AU2013294146A AU2013294146B2 (en) | 2012-07-23 | 2013-07-22 | Ship monitoring device |
| CN201380030403.4A CN104379439B (zh) | 2012-07-23 | 2013-07-22 | 船舶监视装置 |
Applications Claiming Priority (2)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| JP2012-162462 | 2012-07-23 | ||
| JP2012162462A JP5800151B2 (ja) | 2012-07-23 | 2012-07-23 | 船舶監視装置 |
Publications (1)
| Publication Number | Publication Date |
|---|---|
| WO2014017418A1 true WO2014017418A1 (ja) | 2014-01-30 |
Family
ID=49997230
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| PCT/JP2013/069740 Ceased WO2014017418A1 (ja) | 2012-07-23 | 2013-07-22 | 船舶監視装置 |
Country Status (8)
| Country | Link |
|---|---|
| US (1) | US9422040B2 (ja) |
| EP (1) | EP2876033B1 (ja) |
| JP (1) | JP5800151B2 (ja) |
| KR (1) | KR101579172B1 (ja) |
| CN (1) | CN104379439B (ja) |
| AU (1) | AU2013294146B2 (ja) |
| NO (1) | NO2876033T3 (ja) |
| WO (1) | WO2014017418A1 (ja) |
Cited By (1)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| US9937725B1 (en) * | 2017-02-17 | 2018-04-10 | Funai Electric Co., Ltd. | Fluidic dispensing device |
Families Citing this family (1)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JP7031122B2 (ja) * | 2017-02-07 | 2022-03-08 | 横浜ゴム株式会社 | 空気式防舷材のモニタリングシステム |
Citations (6)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JPS63152249A (ja) * | 1986-12-17 | 1988-06-24 | Nec Corp | デ−タ伝送方式 |
| JPS644144A (en) * | 1987-06-26 | 1989-01-09 | Nec Corp | Data transfer system |
| WO1999020845A1 (en) | 1997-10-22 | 1999-04-29 | The Yokohama Rubber Co., Ltd. | Fender and a management system therefor |
| JP2007004428A (ja) | 2005-06-23 | 2007-01-11 | Furuno Electric Co Ltd | 他船ターゲット表示装置 |
| WO2008053887A1 (fr) | 2006-10-31 | 2008-05-08 | The Yokohama Rubber Co., Ltd. | Procédé et système d'assistance au pilotage/amarrage d'un navire |
| JP2010175298A (ja) | 2009-01-27 | 2010-08-12 | Yokohama Rubber Co Ltd:The | 空気式防舷材の空気圧監視装置及びその集中管理システム |
Family Cites Families (3)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN101441471B (zh) * | 2008-12-29 | 2012-02-08 | 山东大学 | 一种船舶自动识别监视系统 |
| EP2581497B1 (en) * | 2010-06-11 | 2014-05-21 | The Yokohama Rubber Co., Ltd. | Pneumatic fender management system |
| US20130278441A1 (en) * | 2012-04-24 | 2013-10-24 | Zetta Research and Development, LLC - ForC Series | Vehicle proxying |
-
2012
- 2012-07-23 JP JP2012162462A patent/JP5800151B2/ja active Active
-
2013
- 2013-07-22 EP EP13823802.7A patent/EP2876033B1/en not_active Not-in-force
- 2013-07-22 KR KR1020147034488A patent/KR101579172B1/ko not_active Expired - Fee Related
- 2013-07-22 CN CN201380030403.4A patent/CN104379439B/zh not_active Expired - Fee Related
- 2013-07-22 US US14/406,646 patent/US9422040B2/en not_active Expired - Fee Related
- 2013-07-22 WO PCT/JP2013/069740 patent/WO2014017418A1/ja not_active Ceased
- 2013-07-22 NO NO13823802A patent/NO2876033T3/no unknown
- 2013-07-22 AU AU2013294146A patent/AU2013294146B2/en not_active Ceased
Patent Citations (6)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JPS63152249A (ja) * | 1986-12-17 | 1988-06-24 | Nec Corp | デ−タ伝送方式 |
| JPS644144A (en) * | 1987-06-26 | 1989-01-09 | Nec Corp | Data transfer system |
| WO1999020845A1 (en) | 1997-10-22 | 1999-04-29 | The Yokohama Rubber Co., Ltd. | Fender and a management system therefor |
| JP2007004428A (ja) | 2005-06-23 | 2007-01-11 | Furuno Electric Co Ltd | 他船ターゲット表示装置 |
| WO2008053887A1 (fr) | 2006-10-31 | 2008-05-08 | The Yokohama Rubber Co., Ltd. | Procédé et système d'assistance au pilotage/amarrage d'un navire |
| JP2010175298A (ja) | 2009-01-27 | 2010-08-12 | Yokohama Rubber Co Ltd:The | 空気式防舷材の空気圧監視装置及びその集中管理システム |
Cited By (1)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| US9937725B1 (en) * | 2017-02-17 | 2018-04-10 | Funai Electric Co., Ltd. | Fluidic dispensing device |
Also Published As
| Publication number | Publication date |
|---|---|
| CN104379439B (zh) | 2016-11-09 |
| NO2876033T3 (ja) | 2018-03-17 |
| EP2876033A4 (en) | 2016-03-30 |
| US9422040B2 (en) | 2016-08-23 |
| EP2876033A1 (en) | 2015-05-27 |
| KR20150006887A (ko) | 2015-01-19 |
| JP2014019380A (ja) | 2014-02-03 |
| KR101579172B1 (ko) | 2015-12-21 |
| AU2013294146B2 (en) | 2015-08-13 |
| AU2013294146A1 (en) | 2015-01-22 |
| JP5800151B2 (ja) | 2015-10-28 |
| EP2876033B1 (en) | 2017-10-18 |
| US20150112519A1 (en) | 2015-04-23 |
| CN104379439A (zh) | 2015-02-25 |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| US9334029B2 (en) | Ship monitoring device | |
| JP4716214B2 (ja) | 船舶の入出港離着桟支援方法およびシステム | |
| US10526059B2 (en) | Ship vicinity information display device and method of displaying information of vicinity of ship | |
| US8041473B2 (en) | Method and system for assisting steering and mooring alongside of vessels | |
| CN205940569U (zh) | 一种基于ecdis和通信网络的船舶引航系统 | |
| CN111801634A (zh) | 接口单元 | |
| KR20100016840A (ko) | 선박 제어 장치 및 그 방법 | |
| JPWO2004019302A1 (ja) | 操船支援システム | |
| KR101866283B1 (ko) | 와이파이통신을 이용한 ais 및 위치정보를 제공하는 소형선박용 무선중계시스템 | |
| JP5800151B2 (ja) | 船舶監視装置 | |
| JP5983922B2 (ja) | 船舶監視装置 | |
| KR20060087360A (ko) | 전자해도가 내장된 선박자동식별장치 | |
| JPH10206178A (ja) | 移動体の誘導システム | |
| JP5796721B2 (ja) | 船舶監視装置 | |
| JP2001317031A (ja) | 埋立工事施工管理システム | |
| AU2004241516A1 (en) | A method and a simulator device for training a pilot of a vessel | |
| KR20070015706A (ko) | 선박용 지피에스 플로터 장치 | |
| CN203950260U (zh) | 电子海图显示与信息系统设备 | |
| JP3118329U (ja) | 離着桟業務支援装置 | |
| JPH07128082A (ja) | 船舶の対岸壁位置測定装置 | |
| KR200381137Y1 (ko) | 전자해도가 내장된 선박자동식별장치 | |
| JP6198374B2 (ja) | 河川マイルマーカー表示システム | |
| AU2016100565A4 (en) | Tensa DMS advanced motion monitoring system | |
| JPS58146878A (ja) | 操船情報伝達装置 |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| 121 | Ep: the epo has been informed by wipo that ep was designated in this application |
Ref document number: 13823802 Country of ref document: EP Kind code of ref document: A1 |
|
| REEP | Request for entry into the european phase |
Ref document number: 2013823802 Country of ref document: EP |
|
| WWE | Wipo information: entry into national phase |
Ref document number: IDP00201407697 Country of ref document: ID Ref document number: 2013823802 Country of ref document: EP |
|
| ENP | Entry into the national phase |
Ref document number: 20147034488 Country of ref document: KR Kind code of ref document: A |
|
| WWE | Wipo information: entry into national phase |
Ref document number: 14406646 Country of ref document: US |
|
| ENP | Entry into the national phase |
Ref document number: 2013294146 Country of ref document: AU Date of ref document: 20130722 Kind code of ref document: A |
|
| NENP | Non-entry into the national phase |
Ref country code: DE |