WO2020238311A1 - 一种雷达信号发送方法及设备 - Google Patents
一种雷达信号发送方法及设备 Download PDFInfo
- Publication number
- WO2020238311A1 WO2020238311A1 PCT/CN2020/077653 CN2020077653W WO2020238311A1 WO 2020238311 A1 WO2020238311 A1 WO 2020238311A1 CN 2020077653 W CN2020077653 W CN 2020077653W WO 2020238311 A1 WO2020238311 A1 WO 2020238311A1
- Authority
- WO
- WIPO (PCT)
- Prior art keywords
- radar
- detection device
- radar detection
- threshold
- propagation delay
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Ceased
Links
Images


Classifications
-
- G—PHYSICS
- G01—MEASURING; TESTING
- G01S—RADIO DIRECTION-FINDING; RADIO NAVIGATION; DETERMINING DISTANCE OR VELOCITY BY USE OF RADIO WAVES; LOCATING OR PRESENCE-DETECTING BY USE OF THE REFLECTION OR RERADIATION OF RADIO WAVES; ANALOGOUS ARRANGEMENTS USING OTHER WAVES
- G01S7/00—Details of systems according to groups G01S13/00, G01S15/00, G01S17/00
- G01S7/02—Details of systems according to groups G01S13/00, G01S15/00, G01S17/00 of systems according to group G01S13/00
- G01S7/023—Interference mitigation, e.g. reducing or avoiding non-intentional interference with other HF-transmitters, base station transmitters for mobile communication or other radar systems, e.g. using electro-magnetic interference [EMI] reduction techniques
-
- G—PHYSICS
- G01—MEASURING; TESTING
- G01S—RADIO DIRECTION-FINDING; RADIO NAVIGATION; DETERMINING DISTANCE OR VELOCITY BY USE OF RADIO WAVES; LOCATING OR PRESENCE-DETECTING BY USE OF THE REFLECTION OR RERADIATION OF RADIO WAVES; ANALOGOUS ARRANGEMENTS USING OTHER WAVES
- G01S13/00—Systems using the reflection or reradiation of radio waves, e.g. radar systems; Analogous systems using reflection or reradiation of waves whose nature or wavelength is irrelevant or unspecified
- G01S13/88—Radar or analogous systems specially adapted for specific applications
- G01S13/93—Radar or analogous systems specially adapted for specific applications for anti-collision purposes
- G01S13/931—Radar or analogous systems specially adapted for specific applications for anti-collision purposes of land vehicles
-
- G—PHYSICS
- G01—MEASURING; TESTING
- G01S—RADIO DIRECTION-FINDING; RADIO NAVIGATION; DETERMINING DISTANCE OR VELOCITY BY USE OF RADIO WAVES; LOCATING OR PRESENCE-DETECTING BY USE OF THE REFLECTION OR RERADIATION OF RADIO WAVES; ANALOGOUS ARRANGEMENTS USING OTHER WAVES
- G01S7/00—Details of systems according to groups G01S13/00, G01S15/00, G01S17/00
- G01S7/52—Details of systems according to groups G01S13/00, G01S15/00, G01S17/00 of systems according to group G01S15/00
- G01S7/534—Details of non-pulse systems
- G01S7/536—Extracting wanted echo signals
-
- G—PHYSICS
- G01—MEASURING; TESTING
- G01S—RADIO DIRECTION-FINDING; RADIO NAVIGATION; DETERMINING DISTANCE OR VELOCITY BY USE OF RADIO WAVES; LOCATING OR PRESENCE-DETECTING BY USE OF THE REFLECTION OR RERADIATION OF RADIO WAVES; ANALOGOUS ARRANGEMENTS USING OTHER WAVES
- G01S13/00—Systems using the reflection or reradiation of radio waves, e.g. radar systems; Analogous systems using reflection or reradiation of waves whose nature or wavelength is irrelevant or unspecified
- G01S13/02—Systems using reflection of radio waves, e.g. primary radar systems; Analogous systems
- G01S13/06—Systems determining position data of a target
- G01S13/08—Systems for measuring distance only
- G01S13/32—Systems for measuring distance only using transmission of continuous waves, whether amplitude-, frequency-, or phase-modulated, or unmodulated
- G01S13/34—Systems for measuring distance only using transmission of continuous waves, whether amplitude-, frequency-, or phase-modulated, or unmodulated using transmission of continuous, frequency-modulated waves while heterodyning the received signal, or a signal derived therefrom, with a locally-generated signal related to the contemporaneously transmitted signal
- G01S13/343—Systems for measuring distance only using transmission of continuous waves, whether amplitude-, frequency-, or phase-modulated, or unmodulated using transmission of continuous, frequency-modulated waves while heterodyning the received signal, or a signal derived therefrom, with a locally-generated signal related to the contemporaneously transmitted signal using sawtooth modulation
-
- G—PHYSICS
- G01—MEASURING; TESTING
- G01S—RADIO DIRECTION-FINDING; RADIO NAVIGATION; DETERMINING DISTANCE OR VELOCITY BY USE OF RADIO WAVES; LOCATING OR PRESENCE-DETECTING BY USE OF THE REFLECTION OR RERADIATION OF RADIO WAVES; ANALOGOUS ARRANGEMENTS USING OTHER WAVES
- G01S7/00—Details of systems according to groups G01S13/00, G01S15/00, G01S17/00
- G01S7/02—Details of systems according to groups G01S13/00, G01S15/00, G01S17/00 of systems according to group G01S13/00
- G01S7/023—Interference mitigation, e.g. reducing or avoiding non-intentional interference with other HF-transmitters, base station transmitters for mobile communication or other radar systems, e.g. using electro-magnetic interference [EMI] reduction techniques
- G01S7/0235—Avoidance by time multiplex
-
- G—PHYSICS
- G01—MEASURING; TESTING
- G01S—RADIO DIRECTION-FINDING; RADIO NAVIGATION; DETERMINING DISTANCE OR VELOCITY BY USE OF RADIO WAVES; LOCATING OR PRESENCE-DETECTING BY USE OF THE REFLECTION OR RERADIATION OF RADIO WAVES; ANALOGOUS ARRANGEMENTS USING OTHER WAVES
- G01S7/00—Details of systems according to groups G01S13/00, G01S15/00, G01S17/00
- G01S7/02—Details of systems according to groups G01S13/00, G01S15/00, G01S17/00 of systems according to group G01S13/00
- G01S7/35—Details of non-pulse systems
-
- G—PHYSICS
- G01—MEASURING; TESTING
- G01S—RADIO DIRECTION-FINDING; RADIO NAVIGATION; DETERMINING DISTANCE OR VELOCITY BY USE OF RADIO WAVES; LOCATING OR PRESENCE-DETECTING BY USE OF THE REFLECTION OR RERADIATION OF RADIO WAVES; ANALOGOUS ARRANGEMENTS USING OTHER WAVES
- G01S7/00—Details of systems according to groups G01S13/00, G01S15/00, G01S17/00
- G01S7/02—Details of systems according to groups G01S13/00, G01S15/00, G01S17/00 of systems according to group G01S13/00
- G01S7/36—Means for anti-jamming, e.g. ECCM, i.e. electronic counter-counter measures
Definitions
- This application relates to the field of communication technology, and in particular to a radar signal sending method and equipment.
- ADAS advanced driving assistance system
- the sensing layer includes vision sensors such as vehicle cameras and radar sensors such as vehicle millimeter wave radar, vehicle laser radar, and vehicle ultrasonic radar.
- Millimeter-wave radar is the first to become the main sensor of unmanned driving system due to its low cost and relatively mature technology.
- ADAS has developed more than ten functions, including adaptive cruise control (ACC), automatic emergency braking (AEB), lane change assistance (lance change assist, LCA), or blind spot monitoring (blind spot monitoring, BSD) and so on are inseparable from vehicle-mounted millimeter wave radar.
- Millimeter waves refer to electromagnetic waves with a wavelength between 1 and 10 mm, and the corresponding frequency range is 30 to 300 GHz.
- the characteristics of millimeter waves are very suitable for the automotive field.
- the beam is much narrower than the microwave beam, and the radar resolution is high; it has strong penetration.
- the laser radar and optical system it has the ability to penetrate smoke, dust and fog, and can work around the clock.
- the embodiments of the present application provide a radar signal sending method and device, which are used to minimize or avoid interference between radars.
- a method for transmitting a radar signal includes: determining a first time domain range, where the first time domain range is a time domain range of L time domain ranges, and L is a positive value greater than 1. Integer; send a first radar signal within the first time domain range; wherein, any one of the L time domain ranges and at least one of the other L-1 time domain ranges Overlap, the absolute value of the difference between the time domain start positions of any two time domain ranges in the L time domain ranges is greater than or equal to the first threshold and less than or equal to the second threshold; the first threshold is based on at least One echo delay and at least one propagation delay are determined, the at least one echo delay includes the first echo delay corresponding to the maximum detection distance of the first radar detection device, and the at least one propagation delay Including the first propagation delay corresponding to the first radar signal.
- the method can be executed by a detection device, such as a radar detection device.
- a detection device such as a radar detection device.
- the radar detection device that executes the method may be referred to as the first radar detection device.
- the absolute value of the difference between the time domain start positions of any two time domain ranges in the L time domain ranges may be greater than or equal to the first threshold and less than or equal to the second threshold, the first threshold It is determined based on at least one echo delay and at least one propagation delay.
- the absolute value of the difference between the time domain starting positions of any two time domain ranges needs to be greater than or equal to at least one echo delay and at least one The maximum value of the propagation delay, and only one radar detection device is allowed to transmit in a time domain. In this way, the radar signal sent by one radar detection device will not fall into the effective receiving area of other radar detection devices.
- the at least one echo delay includes a second echo delay, and the second echo delay is the echo delay corresponding to the maximum detection distance of the second radar detection device, and/or, the at least one propagation
- the time delay includes a second propagation time delay, and the second propagation time delay is the propagation time delay corresponding to the third radar signal corresponding to the third radar detection device;
- the second echo delay is not equal to the first echo delay
- the second propagation delay is not equal to the first propagation delay
- the at least one echo delay may also include echo delays of other radar detection devices. For example, it also includes the second echo time delay corresponding to the second radar detection device.
- the second echo delay may be equal to the first echo delay or not equal to the first echo delay. If the second echo delay is not equal to the first echo delay, it indicates that the second radar detection device is of a different type from the first radar detection device. In this case, the radar signal sent by the second radar detection device is The propagation delay may be equal to or not equal to the first propagation delay, and there is no restriction.
- the at least one propagation delay may also include the propagation delays of radar signals corresponding to other radar detection devices.
- the second propagation delay corresponding to the third radar detection device also includes the second propagation delay corresponding to the third radar detection device.
- the second propagation delay may be equal to the first propagation delay or not equal to the first propagation delay. If the second propagation delay is not equal to the first propagation delay, it indicates that the third radar detection device is of a different type from the first radar detection device. In this case, the third radar signal sent by the third radar detection device is The echo delay may be equal to the first echo delay or not equal to the first echo delay, and there is no restriction.
- the second radar detection device and the third radar detection device may be the same radar detection device, or may also be different radar detection devices.
- the first threshold value is a maximum value among a plurality of first sub-thresholds, and the plurality of first sub-threshold values are based on the at least one response.
- the wave delay and the at least one propagation delay are determined.
- multiple first sub-threshold values can be determined according to at least one echo delay and at least one echo delay, and the maximum value of the multiple first sub-thresholds can be used as the first threshold. Equivalently, if the number of radar detection devices participating in the calculation is greater than 2, a first sub-threshold can be calculated based on every two radar detection devices, and then the maximum value of the obtained first sub-thresholds is used as the first threshold, so that The determined first threshold can meet the conditions of multiple radar detection devices, so that no interference is achieved among multiple radar detection devices.
- the first threshold satisfies the following formula:
- Is the echo delay corresponding to the maximum detection distance of the fourth radar detection device Is the echo delay corresponding to the maximum detection distance of the fifth radar detection device
- Is the propagation delay corresponding to the fourth radar signal Is the propagation delay corresponding to the fifth radar signal
- a 1 is the frequency change of the fourth radar signal per unit time
- a 2 is the frequency change of the fifth radar signal per unit time
- T c is The frequency sweep time of the fourth radar detection device
- the fourth radar signal corresponds to the fourth radar detection device
- the fifth radar signal corresponds to the fifth radar detection device
- ⁇ is a time margin
- the synchronization error is the synchronization error between the fourth radar detection device and the fifth radar detection device.
- the propagation delay corresponding to the fourth radar signal is the maximum propagation delay corresponding to the fourth radar signal
- the fifth radar signal corresponds to The propagation delay of is the maximum propagation delay corresponding to the fifth radar signal.
- a way to calculate the first threshold is given.
- This situation can be applied to, for example, a situation where the positions of the fourth radar detection device and the fifth radar detection device are not fixed.
- the fourth radar detection device and the fifth radar detection device are both on-board radar detection devices.
- the propagation delay corresponding to the fourth radar signal can refer to the maximum propagation delay corresponding to the fourth radar signal.
- the propagation delay corresponding to the fifth radar signal can refer to the maximum propagation delay corresponding to the fifth radar signal. Time delay.
- the fourth radar detection device or the fifth radar detection device may be the first radar detection device, or neither the fourth radar detection device nor the fifth radar detection device is the first radar detection device, which is not specifically limited.
- the second threshold is determined according to the at least one echo delay and the at least one propagation delay.
- the second threshold may also be determined.
- the second threshold may also be determined in other manners, which is not specifically limited.
- the second threshold value is a minimum value among a plurality of second sub-thresholds, and the plurality of second sub-threshold values are based on the at least one response.
- the wave delay and the at least one propagation delay are determined.
- multiple second sub-threshold values can be determined according to at least one echo delay and at least one echo delay, and the smallest value among the multiple second sub-thresholds can be used as the second threshold. Equivalently, if the number of radar detection devices participating in the calculation is greater than 2, a second sub-threshold can be calculated according to every two radar detection devices, and then the minimum value of the second sub-thresholds obtained is used as the second threshold, so that The determined second threshold can conform to the conditions of multiple radar detection devices, so that there is no interference among multiple radar detection devices.
- the second threshold satisfies the following formula:
- Is the echo delay corresponding to the maximum detection range of the sixth radar detection device Is the echo delay corresponding to the maximum detection distance of the seventh radar detection device
- Is the propagation delay corresponding to the sixth radar signal Is the propagation delay corresponding to the seventh radar signal
- a 1 is the frequency change of the sixth radar signal in unit time
- a 2 is the frequency change of the seventh radar signal in unit time
- T c is The frequency sweep time of the sixth radar detection device
- the sixth radar signal corresponds to the sixth radar detection device
- the seventh radar signal corresponds to the seventh radar detection device
- ⁇ is a time margin
- the synchronization error is the synchronization error between the sixth radar detection device and the seventh radar detection device.
- a way to calculate the second threshold is given.
- This situation can be applied to, for example, a situation where the positions of the sixth radar detection device and the seventh radar detection device are not fixed, for example, the sixth radar detection device and the seventh radar detection device are both vehicle-mounted radar detection devices.
- the propagation delay corresponding to the sixth radar signal may refer to the maximum propagation delay corresponding to the sixth radar signal.
- the propagation delay corresponding to the seventh radar signal may refer to the maximum propagation delay corresponding to the seventh radar signal. Time delay.
- the sixth detection device and the fourth detection device may be the same detection device or different detection devices, and the seventh detection device and the fifth detection device may be the same detection device or different detection devices.
- the propagation delay corresponding to the sixth radar signal is the maximum propagation delay corresponding to the sixth radar signal
- the seventh radar signal corresponds to
- the propagation delay of is the maximum propagation delay corresponding to the seventh radar signal.
- the maximum propagation delay of the radar signal may refer to the propagation delay corresponding to the maximum tolerance distance of the corresponding radar detection device.
- the first threshold satisfies the following formula:
- Is the echo delay corresponding to the maximum detection distance of the fourth radar detection device Is the echo delay corresponding to the maximum detection distance of the fifth radar detection device
- Is the propagation delay corresponding to the fourth radar signal Is the propagation delay corresponding to the fifth radar signal
- a 1 is the frequency change of the fourth radar signal per unit time
- a 2 is the frequency change of the fifth radar signal per unit time
- T c is The frequency sweep time of the fourth radar detection device
- the fourth radar signal corresponds to the fourth radar detection device
- the fifth radar signal corresponds to the fifth radar detection device
- ⁇ is a time margin
- the synchronization error is the synchronization error between the fourth radar detection device and the fifth radar detection device.
- Another way of calculating the first threshold is given. This situation can be applied, for example, when the positions of the fourth radar detection device and the fifth radar detection device are fixed.
- the fourth radar detection device and the fifth radar detection device are installed on the RSU, or installed on the base station, or the fourth The radar detection device is installed on the RSU, the fifth radar detection device is installed on the base station, and so on.
- the propagation delay corresponding to the fourth radar signal may refer to the delay of the fourth radar signal from the fourth radar detection device to the fifth radar detection device.
- the propagation delay corresponding to the fifth radar signal may be Refers to the time delay of the fifth radar signal from the fifth radar detection device to the fourth radar detection device.
- the second threshold is determined according to the at least one echo delay and the at least one propagation delay.
- the second threshold value is a minimum value among a plurality of second sub-thresholds, and the plurality of second sub-threshold values are based on the at least one response.
- the wave delay and the at least one propagation delay are determined.
- the second threshold satisfies the following formula:
- Is the echo delay corresponding to the maximum detection distance of the sixth radar detection device Is the echo delay corresponding to the maximum detection range of the seventh radar detection device
- Is the propagation delay corresponding to the sixth radar signal Is the propagation delay corresponding to the seventh radar signal
- a 1 is the frequency change of the sixth radar signal per unit time
- a 2 is the frequency change of the seventh radar signal per unit time
- T c is the sixth radar signal.
- Another way to calculate the second threshold is given.
- This situation can be applied to the situation where the positions of the sixth radar detection device and the seventh radar detection device are fixed, for example, the sixth radar detection device and the seventh radar detection device are installed on the RSU, or installed on the base station, or the sixth The radar detection device is installed on the RSU, the seventh radar detection device is installed on the base station, and so on.
- the propagation delay corresponding to the sixth radar signal may refer to the delay of the sixth radar signal from the sixth radar detection device to the seventh radar detection device.
- the propagation delay corresponding to the seventh radar signal may be Refers to the time delay for the seventh radar signal from the seventh radar detection device to the sixth radar detection device.
- the propagation delay corresponding to the sixth radar signal is that the sixth radar signal reaches the seventh radar from the sixth radar detection device
- the time delay of the detection device, the propagation time delay corresponding to the seventh radar signal is the time delay of the seventh radar signal from the seventh radar detection device to the sixth radar detection device.
- a first detection device is provided, for example, the detection device is the first radar detection device as described above.
- the detection device is used to execute the foregoing first aspect or the method in any possible implementation manner of the first aspect.
- the detection device may include a module for executing the method in the first aspect or any possible implementation of the first aspect, for example, including a processing unit and a transceiver unit. among them,
- the processing unit is configured to determine a first time domain range, where the first time domain range is a time domain range of L time domain ranges, and the L is a positive integer greater than 1;
- the transceiver unit is configured to send a first radar signal within the first time domain
- any one of the L time domain ranges partially overlaps with at least one of the other L-1 time domain ranges, and any two of the L time domain ranges are The absolute value of the difference between the time domain starting positions is greater than or equal to the first threshold and less than or equal to the second threshold; the first threshold is determined based on at least one echo delay and at least one propagation delay, and the at least One echo delay includes the first echo delay corresponding to the maximum detection distance of the first radar detection device, and the at least one propagation delay includes the first propagation delay corresponding to the first radar signal.
- the at least one echo delay includes a second echo delay, and the second echo delay is the echo delay corresponding to the maximum detection distance of the second radar detection device, and/or,
- the at least one propagation delay includes a second propagation delay, and the second propagation delay is a propagation delay corresponding to a third radar signal corresponding to the third radar detection device;
- the second echo delay is not equal to the first echo delay
- the second propagation delay is not equal to the first propagation delay
- the first threshold value is a maximum value among a plurality of first sub-thresholds, and the plurality of first sub-threshold values are based on the at least one response.
- the wave delay and the at least one propagation delay are determined.
- the first threshold satisfies the following formula:
- Is the echo delay corresponding to the maximum detection distance of the fourth radar detection device Is the echo delay corresponding to the maximum detection distance of the fifth radar detection device
- Is the propagation delay corresponding to the fourth radar signal Is the propagation delay corresponding to the fifth radar signal
- a 1 is the frequency change of the fourth radar signal per unit time
- a 2 is the frequency change of the fifth radar signal per unit time
- T c is The frequency sweep time of the fourth radar detection device
- the fourth radar signal corresponds to the fourth radar detection device
- the fifth radar signal corresponds to the fifth radar detection device
- ⁇ is a time margin
- the synchronization error is the synchronization error between the fourth radar detection device and the fifth radar detection device.
- the propagation delay corresponding to the fourth radar signal is the maximum propagation delay corresponding to the fourth radar signal
- the fifth radar signal corresponds to The propagation delay of is the maximum propagation delay corresponding to the fifth radar signal.
- the second threshold is determined according to the at least one echo delay and the at least one propagation delay.
- the second threshold value is a minimum value among a plurality of second sub-thresholds, and the plurality of second sub-threshold values are based on the at least one response.
- the wave delay and the at least one propagation delay are determined.
- the second threshold satisfies the following formula:
- Is the echo delay corresponding to the maximum detection distance of the sixth radar detection device Is the echo delay corresponding to the maximum detection range of the seventh radar detection device
- Is the propagation delay corresponding to the sixth radar signal Is the propagation delay corresponding to the seventh radar signal
- a 1 is the frequency change of the sixth radar signal per unit time
- a 2 is the frequency change of the seventh radar signal per unit time
- T c is The frequency sweep time of the sixth radar detection device
- the sixth radar signal corresponds to the sixth radar detection device
- the seventh radar signal corresponds to the seventh radar detection device
- ⁇ is a time margin
- the synchronization error is the synchronization error between the sixth radar detection device and the seventh radar detection device.
- the propagation delay corresponding to the sixth radar signal is the maximum propagation delay corresponding to the sixth radar signal
- the seventh radar signal corresponds to
- the propagation delay of is the maximum propagation delay corresponding to the seventh radar signal.
- the first threshold satisfies the following formula:
- Is the echo delay corresponding to the maximum detection distance of the fourth radar detection device Is the echo delay corresponding to the maximum detection distance of the fifth radar detection device
- Is the propagation delay corresponding to the fourth radar signal Is the propagation delay corresponding to the fifth radar signal
- a 1 is the frequency change of the fourth radar signal per unit time
- a 2 is the frequency change of the fifth radar signal per unit time
- T c is The frequency sweep time of the fourth radar detection device
- the fourth radar signal corresponds to the fourth radar detection device
- the fifth radar signal corresponds to the fifth radar detection device
- ⁇ is a time margin
- the synchronization error is the synchronization error between the fourth radar detection device and the fifth radar detection device.
- the second threshold is determined according to the at least one echo delay and the at least one propagation delay.
- the second threshold value is a minimum value among a plurality of second sub-thresholds, and the plurality of second sub-threshold values are based on the at least one response.
- the wave delay and the at least one propagation delay are determined.
- the second threshold satisfies the following formula:
- Is the echo delay corresponding to the maximum detection distance of the sixth radar detection device Is the echo delay corresponding to the maximum detection range of the seventh radar detection device
- Is the propagation delay corresponding to the sixth radar signal Is the propagation delay corresponding to the seventh radar signal
- a 1 is the frequency change of the sixth radar signal per unit time
- a 2 is the frequency change of the seventh radar signal per unit time
- T c is the sixth radar signal.
- the propagation delay corresponding to the fourth radar signal is that the fourth radar signal reaches the fifth radar from the fourth radar detection device
- the time delay of the detection device, the propagation time delay corresponding to the fifth radar signal is the time delay of the fifth radar signal from the fifth radar detection device to the fourth radar detection device.
- a second type of detection device is provided.
- the detection device is, for example, the first radar detection device described above.
- the detection device includes a processor, a transmitter, and a receiver, and the processor, the transmitter, and the receiver are coupled with each other to implement the methods described in the first aspect or various possible designs of the first aspect.
- the detection device is a chip provided in a detection device.
- the detection device is a radar.
- the transmitter and receiver are realized by antennas, feeders, codecs, etc. in the communication equipment, or, if the detection device is a chip set in the detection equipment, the transmitter and receiver are, for example, the chips in the chip.
- a communication interface which is connected to the radio frequency transceiver component in the detection device, so as to realize the transmission and reception of information through the radio frequency transceiver component. among them,
- the processor is configured to determine a first time domain range, where the first time domain range is a time domain range of L time domain ranges, and the L is a positive integer greater than 1;
- the transmitter is configured to send a first radar signal within the first time domain
- any one of the L time domain ranges partially overlaps with at least one of the other L-1 time domain ranges, and any two of the L time domain ranges are The absolute value of the difference between the time domain starting positions is greater than or equal to the first threshold and less than or equal to the second threshold; the first threshold is determined based on at least one echo delay and at least one propagation delay, and the at least One echo delay includes the first echo delay corresponding to the maximum detection distance of the first radar detection device, and the at least one propagation delay includes the first propagation delay corresponding to the first radar signal.
- the at least one echo delay includes a second echo delay, and the second echo delay is the echo delay corresponding to the maximum detection distance of the second radar detection device, and/or,
- the at least one propagation delay includes a second propagation delay, and the second propagation delay is a propagation delay corresponding to a third radar signal corresponding to the third radar detection device;
- the second echo delay is not equal to the first echo delay
- the second propagation delay is not equal to the first propagation delay
- the first threshold value is a maximum value among a plurality of first sub-thresholds, and the plurality of first sub-threshold values are based on the at least one response.
- the wave delay and the at least one propagation delay are determined.
- the first threshold satisfies the following formula:
- Is the echo delay corresponding to the maximum detection distance of the fourth radar detection device Is the echo delay corresponding to the maximum detection distance of the fifth radar detection device
- Is the propagation delay corresponding to the fourth radar signal Is the propagation delay corresponding to the fifth radar signal
- a 1 is the frequency change of the fourth radar signal per unit time
- a 2 is the frequency change of the fifth radar signal per unit time
- T c is The frequency sweep time of the fourth radar detection device
- the fourth radar signal corresponds to the fourth radar detection device
- the fifth radar signal corresponds to the fifth radar detection device
- ⁇ is a time margin
- the synchronization error is the synchronization error between the fourth radar detection device and the fifth radar detection device.
- the propagation delay corresponding to the fourth radar signal is the maximum propagation delay corresponding to the fourth radar signal
- the fifth radar signal corresponds to The propagation delay of is the maximum propagation delay corresponding to the fifth radar signal.
- the second threshold is determined according to the at least one echo delay and the at least one propagation delay.
- the second threshold value is a minimum value among a plurality of second sub-thresholds, and the plurality of second sub-threshold values are based on the at least one response.
- the wave delay and the at least one propagation delay are determined.
- the second threshold satisfies the following formula:
- Is the echo delay corresponding to the maximum detection distance of the sixth radar detection device Is the echo delay corresponding to the maximum detection range of the seventh radar detection device
- Is the propagation delay corresponding to the sixth radar signal Is the propagation delay corresponding to the seventh radar signal
- a 1 is the frequency change of the sixth radar signal per unit time
- a 2 is the frequency change of the seventh radar signal per unit time
- T c is The frequency sweep time of the sixth radar detection device
- the sixth radar signal corresponds to the sixth radar detection device
- the seventh radar signal corresponds to the seventh radar detection device
- ⁇ is a time margin
- the synchronization error is the synchronization error between the sixth radar detection device and the seventh radar detection device.
- the propagation delay corresponding to the fourth radar signal is the maximum propagation delay corresponding to the fourth radar signal
- the fifth radar signal corresponds to The propagation delay of is the maximum propagation delay corresponding to the fifth radar signal.
- the first threshold satisfies the following formula:
- Is the echo delay corresponding to the maximum detection distance of the fourth radar detection device Is the echo delay corresponding to the maximum detection distance of the fifth radar detection device
- Is the propagation delay corresponding to the fourth radar signal Is the propagation delay corresponding to the fifth radar signal
- a 1 is the frequency change of the fourth radar signal per unit time
- a 2 is the frequency change of the fifth radar signal per unit time
- T c is The frequency sweep time of the fourth radar detection device
- the fourth radar signal corresponds to the fourth radar detection device
- the fifth radar signal corresponds to the fifth radar detection device
- ⁇ is a time margin
- the synchronization error is the synchronization error between the fourth radar detection device and the fifth radar detection device.
- the second threshold is determined according to the at least one echo delay and the at least one propagation delay.
- the second threshold value is a minimum value among a plurality of second sub-thresholds, and the plurality of second sub-threshold values are based on the at least one response.
- the wave delay and the at least one propagation delay are determined.
- the second threshold satisfies the following formula:
- Is the echo delay corresponding to the maximum detection distance of the sixth radar detection device Is the echo delay corresponding to the maximum detection distance of the seventh radar detection device, Is the propagation delay corresponding to the sixth radar signal, Is the propagation delay corresponding to the seventh radar signal, a 1 is the frequency change of the sixth radar signal per unit time, a 2 is the frequency change of the seventh radar signal per unit time, and T c is the sixth radar signal.
- the propagation delay corresponding to the fourth radar signal is that the fourth radar signal reaches the fifth radar from the fourth radar detection device
- the time delay of the detection device, the propagation time delay corresponding to the fifth radar signal is the time delay of the fifth radar signal from the fifth radar detection device to the fourth radar detection device.
- a third detection device is provided.
- the detection device may be the first radar detection device in the above method design.
- the detection device is a chip provided in a detection device.
- the detection device is a radar.
- the detection device includes: a memory for storing computer executable program codes; and a processor, which is coupled with the memory.
- the program code stored in the memory includes instructions, and when the processor executes the instructions, the third detection device executes the foregoing first aspect or any one of the possible implementation methods of the first aspect.
- the third detection device may also include a communication interface, and the communication interface may be a transceiver in the detection device, for example, realized by the antenna, feeder, and codec in the detection device, or if the fifth detection
- the device is a chip set in the detection device, and the communication interface may be an input/output interface of the chip, such as input/output pins.
- a communication system may include the first detection device described in the second aspect, the second detection device described in the third aspect, or the third detection device described in the fourth aspect , And including other detection devices (for example, including one or more of the second detection device, the third detection device, the fourth detection device, or the fifth detection device); or, the communication system may include the communication system described in the second aspect The first detection device, the second detection device described in the third aspect, or the third detection device described in the fourth aspect, and the target object; or, the communication system may include the first detection device described in the second aspect.
- a detection device, the second detection device of the third aspect, or the third detection device of the fourth aspect, and other detection devices for example, the second detection device, the third detection device, and the fourth detection device
- Device or one or more of the fifth detection device and the target object.
- a computer storage medium stores instructions, which when run on a computer, cause the computer to execute the first aspect or any one of the possible designs of the first aspect The method described.
- a computer program product containing instructions.
- the computer program product stores instructions that, when run on a computer, cause the computer to execute the first aspect or any one of the possible designs of the first aspect. The method described in.
- the absolute value of the difference between the time domain start positions of any two time domain ranges in the L time domain ranges may be greater than or equal to the first threshold value and less than or equal to the second threshold value, such that a The radar signal sent by the radar detection device will not fall into the effective receiving area of other radar detection devices, and will not be processed by other radar detection devices as receiving signals, and the radar signals sent by other radar detection devices will not fall into the first The effective receiving area of a radar detection device will not be processed as a received signal by the first radar detection device. In this way, interference between radar detection devices can be reduced.
- Figure 1 provides a schematic structural diagram of a radar device
- Figure 2 is a schematic diagram of FM continuous wave
- Figure 3 is a schematic diagram of the frequency of the FM continuous wave changing linearly with time
- Figure 4 provides a possible schematic diagram of the frequency changes of the transmitted signal, the reflected signal and the intermediate frequency signal
- Figure 5 is a schematic diagram of mutual interference between vehicle-mounted radars
- Figures 6 and 7 provide a schematic diagram of a possible false intermediate frequency signal
- Figures 8 and 9 provide a schematic diagram of a possible interference signal flooding the target signal
- Figure 10 is a schematic diagram of an interference platform
- Figure 11 is a schematic diagram of an interference platform
- Figure 12 provides a schematic diagram of a possible solution
- Figure 13 provides a schematic diagram of possible false alarm results
- Figure 14 provides a schematic diagram of another possible solution
- Figure 15 provides a schematic diagram of another possible solution
- FIG. 16 is a schematic diagram of a possible application scenario of an embodiment of this application.
- FIG. 17A is a flowchart of a method for sending a radar signal according to an embodiment of the application.
- FIG. 17B is a schematic diagram of a relationship between three time domain ranges provided by an embodiment of this application.
- 18 is a schematic diagram of the time domain range of the fourth radar detection device and the time domain range of the fifth radar detection device in an embodiment of the application;
- FIG. 19 is a schematic diagram of an arrangement of time domain ranges where multiple radars are located in an embodiment of this application.
- 20 is a schematic diagram of the time domain range of the fourth radar detection device and the time domain range of the fifth radar detection device in an embodiment of the application;
- FIG. 21 is a schematic diagram of a radar signal that can be supported within a 1 GHz bandwidth in an embodiment of the application;
- Fig. 22 is a schematic diagram of the time domain range of the fourth radar detection device and the time domain range of the fifth radar detection device in an embodiment of the application;
- FIG. 23 is a schematic diagram of the time domain range of the fourth radar detection device and the time domain range of the fifth radar detection device in an embodiment of the application;
- 24 is a schematic diagram of the time domain range of the fourth radar detection device and the time domain range of the fifth radar detection device in an embodiment of the application;
- FIG. 25 is a schematic structural diagram of a first radar detection device provided by an embodiment of the present application.
- FIG. 26 is a schematic diagram of another structure of the first radar detection device provided by an embodiment of the present application.
- FIG. 27 is a schematic diagram of still another structure of the first radar detection device provided by an embodiment of the present application.
- FIG. 28 is a schematic structural diagram of a device provided by an embodiment of the present application.
- a radar detection device such as a radar, or other devices for detection (eg, ranging).
- Radar or radar device
- the signal emitted by the radar can be a radar signal, and correspondingly, the reflected signal received by the target object can also be a radar signal.
- the emission period of the radar detection device refers to the period during which the radar detection device transmits a complete waveform of the radar signal. Radar detection devices generally send multiple sweep cycles of radar signals in a continuous period of time.
- the initial frequency of the radar detection device At the beginning of a transmission cycle, the radar detection device will transmit a radar signal at a frequency, which is called the initial frequency of the radar detection device. And the transmission frequency of the radar detection device changes during the transmission period based on the initial frequency.
- the sweep bandwidth of the radar detection device the bandwidth occupied by the waveform of the radar signal sent by the radar detection device.
- “sweep frequency bandwidth” is defined for the convenience of explanation, and is technically the bandwidth occupied by the waveform of the radar signal sent by the radar detection device.
- the frequency band occupied by the waveform of the radar signal sent by the radar detection device may be referred to as the sweep frequency band.
- FMCW Frequency modulated continuous wave
- the linear change here generally refers to a linear change within a transmission period.
- the waveform of the chirp continuous wave is generally a sawtooth wave or a triangle wave, or there may be other possible waveforms, such as a stepped frequency waveform.
- the maximum ranging distance of the radar detection device is a parameter related to the configuration of the radar detection device (for example, related to the factory setting parameters of the radar detection device).
- the radar detection device is a radar
- the long-range adaptive cruise control (ACC) radar has a maximum ranging distance of 250m
- the medium-range radar has a maximum ranging distance of 70-150m.
- Intermediate frequency (IF) signal taking the radar detection device as an example, the local oscillator signal of the radar and the reflected signal received by the radar (the signal transmitted by the radar is reflected by the target object) are processed by the mixer The signal after that is the intermediate frequency signal. Specifically, part of the frequency modulated continuous wave signal generated by the oscillator is used as the local oscillator signal, and the other part is used as the transmitting signal to be transmitted through the transmitting antenna, and the reflected signal of the transmitting signal received by the receiving antenna will be mixed with the local oscillator signal to obtain The "intermediate frequency signal". Through the intermediate frequency signal, one or more of the position information, speed information or angle information of the target object can be obtained.
- the position information may be the position information of the target object relative to the current radar
- the speed information may be the speed information of the target object relative to the current radar
- the angle information may be the angle information of the target object relative to the current radar.
- the frequency of the intermediate frequency signal is called intermediate frequency.
- the maximum propagation delay of the radar signal is determined according to the attributes or parameters of the current radar itself.
- the above attributes or parameters may specifically include at least one of the following: detection device (detection as an interference source) Device)
- the transmit power of the radar signal and the sensitivity of the detection device (current detection device) receiver.
- another radar signal will be received by the current radar after a certain propagation time delay.
- the power of the interference signal is greater than the receiver sensitivity, the interference signal will affect the current radar.
- the radar produces interference. If the power of the interference signal is not greater than the receiver sensitivity, the interference signal will not interfere with the current radar, and the interference signal will be processed as noise. Then, after the propagation delay, if the power of the interference signal is equal to the receiver sensitivity, the propagation delay is called the maximum propagation delay of the radar signal.
- At least one means one or more, and "plurality” means two or more.
- “And/or” describes the association relationship of the associated objects, indicating that there can be three relationships, for example, A and/or B, which can mean: A alone exists, A and B exist at the same time, and B exists alone, where A, B can be singular or plural.
- the character “/” generally indicates that the associated objects are in an "or” relationship.
- "The following at least one item (a)” or similar expressions refers to any combination of these items, including any combination of a single item (a) or plural items (a).
- at least one item (a) of a, b, or c can represent: a, b, c, ab, ac, bc, or abc, where a, b, and c can be single or multiple .
- ordinal numbers such as "first" and “second” mentioned in the embodiments of this application are used to distinguish multiple objects, and are not used to limit the order, timing, priority, or order of multiple objects. Importance.
- the first information and the second information are only used to distinguish different information, but do not indicate the difference in content, priority, sending order, or importance of the two types of information.
- ADAS Advanced Driver Assistance Systems
- the sensing layer is compared to the “eyes” of the car, including vision sensors such as on-board cameras and radar-based sensors such as on-board millimeter wave radar, on-board Lidar, and on-board ultrasonic radar.
- Millimeter-wave radar is the first to become the main sensor of unmanned driving system due to its low cost and relatively mature technology.
- ADAS has developed more than ten functions. Among them, adaptive cruise, automatic emergency braking, lane change assistance, or blind spot monitoring are all inseparable from vehicle-mounted millimeter wave radar.
- Millimeter waves refer to electromagnetic waves with a wavelength between 1 and 10 mm, and the corresponding frequency range is 30 to 300 GHz. In this frequency band, the characteristics of millimeter waves make it very suitable for the automotive field. Large bandwidth: abundant frequency domain resources, low antenna sidelobe, which is conducive to imaging or quasi-imaging; short wavelength: the volume of radar equipment and antenna aperture can be reduced, and the weight is reduced; narrow beam: the beam requirement of millimeter wave under the same antenna size The beam is much narrower than the microwave, and the radar resolution is high; strong penetration: Compared with laser radar and optical systems, it has the ability to penetrate smoke, dust and fog, and can work around the clock.
- Vehicle-mounted millimeter wave radar systems generally include oscillators, transmitting antennas, receiving antennas, mixers, processors, and controllers. As shown in Figure 1, it is the working principle diagram of millimeter wave radar.
- the oscillator generates a radar signal whose frequency increases linearly with time.
- the radar signal is generally a frequency modulated continuous wave. Part of the radar signal is output to the mixer through the directional coupler as the local oscillator signal, and part is transmitted through the transmitting antenna.
- the receiving antenna receives the transmitted radar signal and the radar signal reflected back after encountering the object in front of the vehicle, the mixer Mix the received radar signal with the local oscillator signal to obtain an intermediate frequency signal.
- the intermediate frequency signal contains the relative distance, speed, and angle of the target object and the radar system.
- the intermediate frequency signal is sent to the processor after being amplified by a low-pass filter, and the processor processes the received signal, generally performing fast Fourier transform and spectrum analysis on the received signal to obtain the target object relative to The distance, speed and angle of the radar system. Finally, the processor can output the obtained information to the controller to control the behavior of the vehicle.
- the FM continuous wave waveform of millimeter wave radar is generally sawtooth wave or triangular wave.
- the following uses sawtooth wave as an example to introduce the distance measurement principle of millimeter wave radar in detail.
- the distance measurement principle of triangle wave is similar.
- the chirp continuous wave is a signal whose frequency changes linearly with time.
- the period of the FM continuous wave is T c
- the slope is a 0
- the bandwidth is B
- its starting frequency is b 0 .
- a frequency modulated continuous wave signal shown in Fig. 2 is also called a chirp signal.
- the equivalent baseband signal of the single-period FM continuous wave output by the oscillator of the millimeter wave radar can be expressed as:
- A represents the amplitude of the equivalent baseband signal
- a 0 represents the slope of the equivalent baseband signal
- b 0 represents the intercept of the equivalent baseband signal on the Y axis
- exp represents the exponential function of e. Since frequency is defined as the rate of change of phase with respect to time. Therefore, the frequency of the above equivalent baseband signal is:
- Equation 1.2 The image of Equation 1.2 is shown in Figure 3.
- the equivalent baseband signal from the oscillator is up-converted and radiated from the transmitting antenna of the millimeter wave radar.
- the transmitted signal can be expressed as:
- the signal After the signal encounters an obstacle, it will be reflected back and then received by the millimeter wave radar.
- the waveform of the transmitted signal has the same shape as the waveform of the reflected signal, but the waveform of the reflected signal has a time delay ⁇ relative to the waveform of the transmitted signal.
- the echo signal is the reflected signal.
- the received reflected signal can be expressed as:
- the signal obtained after down-conversion of the received equivalent baseband signal is:
- A′ is the signal amplitude of the equivalent baseband signal sent by the oscillator after transmitting antenna gain, target reflection, propagation loss, and receiving antenna gain
- ⁇ is the radar signal sent from the millimeter wave radar transmitter to the millimeter wave radar The receiver receives the echo signal (that is, the reflected signal), and the time delay between them, as shown in Figure 4, this time delay is twice the distance/speed of light.
- ⁇ max represents the echo delay corresponding to the maximum detection distance of the millimeter wave radar, that is, ⁇ max is the distance between the millimeter wave radar and the target object. At the maximum distance that can be detected, the time delay of the reflected signal received by the millimeter wave radar relative to the transmitted signal.
- the relationship between ⁇ and the target distance d can be expressed as:
- c is the speed of light.
- the mixer of this millimeter wave radar mixes the received signal with the local oscillator signal, and after passing through a low-pass filter, outputs an intermediate frequency signal, which is expressed as:
- the intermediate frequency signal is sent to the processor of the millimeter-wave radar for processing such as fast Fourier transform, and the frequency f IF of the intermediate frequency signal can be obtained.
- the frequency of the intermediate frequency signal is the product of the slope of the waveform of the transmitted signal and the time delay ⁇ , namely:
- the distance d between the millimeter wave radar and the target object is:
- the frequency difference between the transmitted signal and the received signal that is, the frequency of the intermediate frequency signal
- the time delay are linear: the farther the target object, the later the time to receive the reflected signal, then the reflection The greater the frequency difference between the signal and the transmitted signal. Therefore, the distance between the radar and the target object can be determined by judging the frequency of the intermediate frequency signal.
- the foregoing processing of radar signals is only an example, and there is no restriction on the specific radar processing.
- FIG. 5 is a schematic diagram of mutual interference between vehicle-mounted radars.
- the radar 1 sends out a transmission signal and receives the reflected signal from the transmission signal on the target object. While radar 1 receives the reflected signal, the receiving antenna of radar 1 also receives the transmitted signal or reflected signal of radar 2, then the transmitted signal of radar 2 received by radar 1 or the reflected signal of radar 2 is interference for radar 1. signal.
- Radar 1 be an observation radar
- the slope of the FM continuous wave is a 0
- the intercept is b 0
- the period is T c .
- Radar 2 is a jamming radar.
- the slope of the FM continuous wave is a 1
- the intercept is b 1.
- b 0 b 1 .
- the echo delay corresponding to the maximum ranging distance of radar 1 is ⁇ max (that is, the time delay calculated by adding the maximum detection distance of the radar in formula 1.6.
- the maximum detection distance of radar is 250 m, which is put into formula 1.6
- the calculated time delay is 1.67 ⁇ s)
- the time delay of the jamming signal of radar 2 reaching the receiver of radar 1 is ⁇ 1 .
- the time interval for the radar to detect the received signal is ⁇ max ⁇ T c .
- radar 1 receives the signal shown by the dotted line of the corresponding frequency, then radar 1 thinks there is "Target object 1"exists; radar 1 detects the signal shown by the dotted line and the reflected signal shown by the solid line during the signal processing time interval ( ⁇ max ⁇ T c ), then radar 1 will show the received dotted line The signal is mistaken for the reflection signal of an object in front, and a false intermediate frequency signal will be generated at this time. Radar 1 undergoes a fast Fourier transform and performs spectrum analysis to find two peaks. As shown in Figure 7, each peak corresponds to a target object. Radar 1 considers that "target object 1" and "target object 2" exist at the same time.
- Radar 1 mistakenly believes that there is “target object 1" ahead, but in fact the "target object 1" does not exist, which is called “ghost” or "false alarm”. After the false alarm is generated, the self-driving car will slow down or brake suddenly when there is no object ahead, which reduces the driving comfort.
- FIGs 8 and 9 are schematic diagrams of a possible interference signal overwhelming the target signal.
- the radar 1 transmits a signal to a target object and receives a reflected signal from the target object.
- the receiving antenna of radar 1 receives the transmitted signal or reflected signal of radar 2 (dotted line).
- the time interval ( ⁇ max ⁇ T c ) of the signal detection of radar 1 the reflected signal of radar 1 and the related signal of radar 2 will be detected at the same time After mixing the detected relevant signal of radar 2 with the reflected signal of radar 1, an intermediate frequency signal containing various frequency components will be generated.
- the signal received at a certain moment or period of time may be an interference signal, or may be a reflected signal of a target object, and the relative changes in the frequency of the transmitted/reflected signal through time can be Clearly reflect the detection situation of the radar. Therefore, in the subsequent explanations of the embodiments of the present application, most of the graphs reflecting the slope of the transmitted/reflected signal (the range of frequency change per unit time) are used to represent the mutual interference between radars.
- FIG. 12 is a schematic diagram of a possible solution.
- the slope and transmission period of the signal of radar 1 are inconsistent with those of radar 2.
- the intermediate frequency signal of constant frequency will not be generated. Because only the intermediate frequency signal with a constant frequency will be reflected as a peak signal in the spectrum analysis, this method can reduce the probability of ghost occurrence.
- FIG. 13 is a schematic diagram of a possible missed detection result. The consequence is that there is an obstacle in front of the vehicle but it is not detected, resulting in missed detection, which has a bad influence on the safety of vehicle driving, especially the safety of unmanned vehicles.
- Figure 14 is a schematic diagram of another possible solution.
- the technology used in this solution is radar waveform frequency shift technology. If the radar detects interference from other radars in its sweep frequency band, it will jump to another frequency band to prevent interference between multiple radars.
- the frequency shift interval in the frequency shift technology can be greater than the radar sweep bandwidth, as shown in Figure 14. In this case, the radar waveforms are completely frequency divided and there is no overlap, but the frequency shift interval is set so that The frequency domain resources are occupied too much, and the frequency domain resources allocated to vehicle radars are currently limited. Or the frequency shift technology is still applied, but after the radar detects interference generated by other radars in the working frequency band, it performs random frequency shift (shift), as shown in Figure 15.
- Figure 15 is a schematic diagram of another possible solution.
- the interference can be reduced to a certain extent, but the completely randomized frequency shift (shift) will inevitably cause the two radar waveforms after the frequency shift (shift) to be too close in the frequency domain, resulting in ghost or interference signals.
- the increased strength of the object leads to missed inspections.
- the absolute value of the difference between the time domain start positions of any two time domain ranges in the L time domain ranges may be greater than or equal to the first threshold and less than or equal to the second threshold, the first threshold It is determined based on at least one echo delay and at least one propagation delay.
- the absolute value of the difference between the time domain starting positions of any two time domain ranges needs to be greater than or equal to at least one echo delay and at least one The maximum value of the propagation delay, and only one radar detection device is allowed to transmit in a time domain range, so that the radar signal sent by one radar detection device will not fall within the target echo observation range of other radar detection devices. The radar signals sent by other radar detection devices will not fall within the target echo observation range of the first radar detection device. In this way, interference between radar detection devices can be reduced.
- FIG. 16 it is a schematic diagram of a possible application scenario of an embodiment of this application.
- the above application scenarios can be unmanned driving, autonomous driving, intelligent driving, networked driving, etc.
- Radar detection devices can be installed in motor vehicles (such as unmanned vehicles, smart cars, electric vehicles, digital cars, etc.), drones, rail cars, bicycles, signal lights, speed measuring devices or network equipment (such as base stations in various systems, Terminal equipment) and so on.
- the embodiments of the present application are not only applicable to radar detection devices between cars, but also radar detection devices between cars and drones and other devices, or radar detection devices between other devices.
- the radar detection device can be installed on a mobile device, such as a vehicle as a vehicle-mounted radar detection device, or can also be installed on a fixed device, such as a roadside unit (RSU) and other equipment.
- a mobile device such as a vehicle as a vehicle-mounted radar detection device
- RSU roadside unit
- the embodiment of the present application does not limit the installation position and function of the radar detection device.
- the embodiment of this application may be executed by a detection device.
- the detection device that executes the method provided in the embodiment of this application may be referred to as the first detection device.
- the following embodiments of the present application mostly use the detection device as a radar detection device and the radar detection device as a radar, such as a millimeter wave radar, as an example to explain and describe the embodiments.
- the embodiment of the present application does not limit the detection device to only a radar detection device, nor does it limit the radar detection device to only a millimeter wave radar or radar.
- multiple radar detection devices that transmit radar signals in corresponding time domains among the L time domains may have the same frequency sweep period.
- the radar detection device 1 transmits radar signals in the first time domain range of the multiple time domain ranges, and the radar detection device transmits radar signals in the second time domain range of the multiple time domain ranges 2. Then the sweep period of the radar detection device 1 is the same as the sweep period of the radar detection device 2.
- the signal sent by the detection device may be a radio signal. If the detection device is a radar detection device as an example, then the signal sent by the detection device can be considered as a radar signal. In the embodiment of the present application, the detection device is a radar detection device, and the signal sent by the detection device is a radar signal as an example.
- the time domain range can refer to a continuous period of time, and the radar detection device can send one or more frequency sweep cycles during this continuous period of time.
- the time domain range may also be referred to as time domain unit, time domain resource, time unit, time resource or duration, etc., and there is no restriction on the specific name.
- the length of a time domain range can be equal to the transmission period of the radar detection device (or called the sweep period, sweep duration, etc.). It can also be said that the time domain length of each of the L time domain ranges may be the frequency sweep period of the radar detection device.
- the length of a time domain range can be equal to an integer multiple of the frequency sweep period of the radar detection device. For example, if the duration of a certain time domain is 500 sweep cycles, the corresponding radar detection device needs to transmit 500 sweep cycles of radar signals within this time domain.
- the time domain lengths of the L time domain ranges are the same. In other scenarios, the time domain lengths of the L time domain ranges may not be exactly the same.
- the radar detection device transmits the radar signal at a certain transmission timing.
- the actual transmission time of the radar signal There may be errors, which can also be called signal transmission errors.
- the error caused by the accuracy of GPS.
- differences in the production and manufacturing of different radar detection devices may cause some errors in signal transmission.
- the methods provided in the embodiments of the present application can be considered in specific implementation.
- the embodiments of the present application may also ignore these errors, and describe the solution according to a unified standard and transmission timing. It should be clear that when the embodiments of the present application describe the technical solutions, whether the above-mentioned errors are considered or ignored, they do not substantially affect the implementation and beneficial effects of the embodiments of the present application.
- the embodiment of the present application provides a method for sending a radar signal.
- FIG. 17A is a flowchart of the method.
- the application of this method to the network architecture shown in FIG. 16 is taken as an example.
- the method provided by the embodiment shown in FIG. 17A may be executed by the radar detection device in the network architecture shown in FIG. 16, for example, the radar detection device is called the first radar detection device.
- the signals sent by the radar detection device can all be radar signals, and naturally, the received echo signals can also be radar signals.
- the first radar detection device determines a first time domain range.
- the first time domain range is a time domain range of L time domain ranges, and the L is a positive integer greater than 1.
- any one of the L time domain ranges partially overlaps with at least one of the other L-1 time domain ranges, and the time domains of any two of the L time domain ranges start
- the absolute value of the difference in position is greater than or equal to the first threshold and less than or equal to the second threshold.
- the first threshold is determined based on at least one echo delay and at least one propagation delay.
- the at least one echo delay includes the echo delay corresponding to the maximum detection range of the first radar detection device (for example, called the first echo Time delay)
- the at least one propagation time delay includes the propagation time delay corresponding to the first radar signal sent by the first radar detection device (for example, referred to as the first propagation time delay).
- the “L” here can be pre-defined or configured, or it can be determined according to preset rules.
- "L” can be embodied as there are L candidate time-domain grid points in a frequency sweep period, and each time-domain grid point and a certain duration form a time-domain range.
- the time domain grid point may be the start position or the end position of the time domain range, or the middle position of the time domain range.
- the radar detection device will work for a certain period of time, this application uses the "time domain range" to explain and explain the solution.
- the time domain range can be defined by time domain grid points and duration.
- S1701 can be replaced by "S1701, the first radar detection device determines the first time domain grid point", and the first detection device is based on the first time domain.
- the field grid points determine the first time domain range. Further, the first time domain grid point is one of L time domain grid points.
- the L time domain ranges may be referred to as a set of time domain ranges.
- the L time domain ranges and each time domain range within the L time domain ranges can also be defined as other names. No matter how the names are defined, the L time domain ranges refer to a larger granularity. Time length, each time domain range refers to a smaller granular time length.
- any one of the L time domain ranges partially overlaps (or incompletely overlaps) with at least one of the other L-1 time domain ranges.
- the so-called two time domain ranges completely overlapping means that the two time domain ranges are completely the same, for example, the time domain start position of the two time domain ranges is the same and the time domain end position is the same; or the two time domain ranges completely overlap , Means that one of the two time domains is completely contained in the other time domain. Not completely overlapping means that the two time domains have an intersection, but the two time domains are not exactly the same.
- the time domain start position of the two time domain scopes is the same but the time domain end position is different, or two time domains
- the time domain start positions of the ranges are different and the time domain end positions are the same, or the time domain start positions of the two time domain ranges are different and the time domain end positions are different.
- the above-mentioned design method with multiple time domain ranges partially overlapping can avoid waste of time domain resources caused by completely separating the sweep periods of multiple radar detection devices in the time domain, and can effectively use time domain resources to reduce time At the cost of domain resources, higher anti-jamming performance can be achieved, while at the same time it can support a greater number of radar detection devices to communicate.
- the absolute value of the difference between the time domain start positions of any two time domain ranges in the L time domain ranges is greater than or equal to the first threshold and less than or equal to the second threshold, which may include the following two cases.
- the starting positions of the time domains of the L time domain ranges are equally spaced in the time domain.
- the absolute value of the difference between the start positions of any two “adjacent” time domains in the time domain in the L time domain ranges is equal to F, then any two time domains
- the absolute value of the difference between the time domain start positions of the “non-adjacent” time domain range may be equal to X times F, and X is a positive integer greater than 1.
- the time domain starting positions of the L time domain ranges are not equally spaced in the time domain.
- the absolute value of the difference between the start positions of the two time domains in the L time domains is the smallest, then the difference between the start positions of the two time domains The absolute value of the value is equal to F.
- the absolute value of the difference between the time domain starting positions of any two time domain ranges in the L time domain ranges can be greater than F.
- Figure 17B illustrates an optional case when L is equal to 3.
- the three time domain ranges can be called the first time domain range, the second time domain range, and the third time domain range, respectively.
- any one time domain range partially overlaps with the other two time domain ranges.
- the overlapping area between the first time domain and the second time domain is marked as overlapping area 1
- the overlapping area between the first time domain and the third time domain is marked as overlapping area 3.
- the overlapping area between the two time domains and the third time domain is marked as overlapping area 2.
- the absolute value of the difference between the time domain start positions of any two of the three time domain ranges is greater than or equal to the first threshold and less than or equal to the second threshold.
- the absolute value of the difference between the time domain start position of the first time domain range and the start position of the second time domain range is the length of interval area 1
- the time domain start position of the second time domain range is the length of interval 2
- the absolute value of the difference from the start position of the third time domain range is the length of interval 2
- the absolute value of is the length of interval 3.
- the length of the interval area 1, the length of the interval area 2, and the length of the interval area 3 are all greater than or equal to the first threshold and less than or equal to the second threshold.
- the L time domain ranges include the first time domain, the second time domain, and the third time domain in the order of the time domain from front to back, it is called the first time domain.
- the absolute value of the difference between the time domain start position of the second time domain range and the time domain start position is the first absolute value, which is called the difference between the time domain start position of the second time domain range and the third time domain range
- the first absolute value may be equal to or not equal to the second absolute value.
- the first absolute value and the second absolute value are both greater than or equal to the first threshold and less than or equal to the second threshold.
- the first radar detection device may be a radar detection device that needs to send a radar signal. Therefore, the first radar detection device may select the first time domain range from L time domain ranges to send the radar signal.
- a second radar detection device which may also be a radar detection device that needs to send a radar signal.
- the second radar detection device may also select a corresponding time domain range from L time domain ranges to send a radar signal.
- the time domain range and the radar detection device should have a one-to-one correspondence, that is, the second radar detection device can select the second time domain range from the L time domain ranges to send the radar signal, and the second time domain range It is not the same time domain range as the first time domain range. But there is another possibility.
- the second radar detection device needs to select the time domain range, it is possible that all L time domain ranges are already occupied. Then the second radar detection device can select one from the occupied L time domain ranges. Time domain range to send.
- the categories of the first radar detection device and the second radar detection device may be different or may be the same.
- the first radar detection device belongs to the first type of radar detection devices in the N type radar detection device
- the second radar detection device belongs to the second type of radar detection device in the N type radar detection device.
- the radar detection device may have multiple parameters.
- one parameter is the echo delay corresponding to the maximum detection distance of the radar detection device
- another parameter is the propagation delay of the radar signal sent by the radar detection device.
- the values of at least one of the two parameters are different, it indicates that the two radar detection devices are of different types.
- the echo delay corresponding to the maximum detection distance of the first radar detection device is different from the echo delay corresponding to the maximum detection distance of the second radar detection device, indicating that the types of the first radar detection device and the second radar detection device are different
- the propagation delay of the radar signal sent by the first radar detection device is different from the propagation delay of the radar signal sent by the second radar detection device, indicating that the first radar detection device and the second radar detection device are of different types
- the echo delay corresponding to the maximum detection distance of the first radar detection device is different from the echo delay corresponding to the maximum detection distance of the second radar detection device, and the propagation delay of the radar signal sent by the first radar detection device
- the propagation delay of the radar signal sent by the second radar detection device is different, indicating that the first radar detection device and the second radar detection device are of different types; or, the echo delay corresponding to the maximum detection distance of the first radar detection device
- the echo delay corresponding to the maximum detection distance of the second radar detection device is the same, and the propagation delay of the radar signal sent by the
- the at least one echo delay may also include the echo delay of other radar detection devices. It can be understood that the at least one echo delay may correspond to the at least one radar. Detection device.
- the echo delay corresponding to the maximum detection distance of the second radar detection device may be referred to as the second echo delay, and the second echo delay may be included in the at least one echo delay.
- the second echo delay may be equal to the first echo delay or not equal to the first echo delay. If the second echo delay is not equal to the first echo delay, it indicates that the second radar detection device and the first radar detection device are of different types.
- the radar signal sent by the second radar detection device ( For example, the propagation delay of the second radar signal may be equal to the first propagation delay or not equal to the first propagation delay, and there is no restriction.
- the at least one propagation delay may also include the propagation delays of radar signals (or sent radar signals) corresponding to other radar detection devices, which can be understood as at least one
- the propagation delay may correspond to at least one radar detection device.
- the propagation delay of the radar signal (for example, the third radar signal) sent by the third radar detection device is called the second propagation delay, and the second propagation delay may be included in the at least one propagation delay.
- the second propagation delay may be equal to the first propagation delay or not equal to the first propagation delay. If the second propagation delay is not equal to the first propagation delay, it indicates that the third radar detection device is of a different type from the first radar detection device. In this case, the third radar signal sent by the third radar detection device is The echo delay may be equal to the first echo delay or not equal to the first echo delay, and there is no restriction.
- the second radar detection device and the third radar detection device may be the same radar detection device, or may also be different radar detection devices.
- the echo delay corresponding to the radar detection device refers to the time when the radar detection device sends out the radar signal when the radar detection device is detecting, and the reflected signal after the sent radar signal is reflected after reaching the target object is detected by the radar The moment the device receives, the time difference between these two moments.
- the echo delay corresponding to the maximum detection distance of the radar detection device means that when the radar detection device is detecting, if the distance between the detected target object and the radar detection device is the maximum detection distance supported by the radar detection device, then The time difference between the time when the radar detection device sends out the radar signal and the time when the reflected signal after the sent radar signal reaches the target object is received by the radar detection device.
- the first threshold may be determined based on at least one echo delay and at least one propagation delay.
- multiple first sub-threshold values may be determined according to at least one echo delay and at least one propagation delay, and the maximum value of the multiple first sub-threshold values may be used as the first threshold.
- the second threshold may also be determined based on at least one echo delay and at least one propagation delay.
- multiple second sub-threshold values can be determined based on at least one echo delay and at least one propagation delay, and the smallest value among the multiple second sub-thresholds can be used as the second threshold. It should be noted here that the multiple first sub-thresholds and the multiple second sub-thresholds are all determined according to at least one echo delay and at least one propagation delay, and the specific determination methods may be different.
- the first sub-threshold value can be obtained based on every two radar detection devices, that is, for every two radar detection devices, a first sub-threshold value can be obtained, and then all The maximum value of the multiple first sub-thresholds obtained is used as the first threshold.
- N radar detection devices a total of First sub-threshold
- Each of the first sub-thresholds is based on the echo delay corresponding to the maximum detection distance of the two radar detection devices in the N radar detection devices, and the radar signal sent by the two radar detection devices If the propagation delay is determined, then the first threshold can be The maximum value of the first sub-threshold.
- the second sub-threshold value can be obtained according to every two radar detection devices, that is, for every two radar detection devices, a second sub-threshold value can be obtained, and then the obtained multiple second sub-threshold values can be obtained.
- the minimum value of the threshold is used as the second threshold. For example, according to N radar detection devices, a total of Second sub-threshold, Each of the second sub-thresholds is based on the echo delay corresponding to the maximum detection distance of the two radar detection devices in the N radar detection devices, and the radar signal sent by the two radar detection devices If the propagation delay is determined, then the second threshold can be The minimum value of the second sub-threshold.
- the N radar detection devices may all be radar detection devices that need to send radar signals, in other words, they may all be radar detection devices that need to select a time domain range from multiple time domain ranges to send radar signals, or N radar detection devices Some radar detection devices in the device may not need to select a time domain range from multiple time domain ranges.
- the embodiment of the present application does not limit what exactly the N radar detection devices include.
- the types of radar detection devices are not distinguished. As long as there are two different radar detection devices, the first sub-threshold or the second sub-threshold can be obtained from the two radar detection devices.
- the types of radar detection devices may be different or the same.
- the first sub-threshold or the second sub-threshold value can be obtained according to different types of radar detection devices, or the first sub-threshold value can be obtained according to the same category of radar detection devices.
- the sub-threshold or the second sub-threshold can be obtained according to different types of radar detection devices, or the first sub-threshold value can be obtained according to the same category of radar detection devices.
- the first sub-threshold value can be obtained according to each two types of radar detection devices, that is, for each two types of radar detection devices, a first sub-threshold value can be obtained, and then all The maximum value of the multiple first sub-thresholds obtained is used as the first threshold. It is also possible to obtain the first sub-threshold value according to each type of radar detection device, that is to say, for each type of radar detection device, one first sub-threshold value can be obtained, and then the obtained multiple first sub-threshold values The maximum value is used as the first threshold.
- a total of First sub-threshold, One of the first sub-thresholds is based on the echo delay corresponding to the maximum detection distance of the two types of radar detection devices in the N-type radar detection device, and the propagation of the radar signals sent by the two types of radar detection devices
- the time delay is determined, or is determined based on the echo delay corresponding to the maximum detection distance of a type of radar detection device in the N type radar detection device, and the propagation delay of the radar signal sent by this type of radar detection device, then,
- the first threshold can be The maximum value of the first sub-threshold.
- the second sub-threshold value can be obtained according to each two types of radar detection devices, that is, for each two types of radar detection devices, a second sub-threshold value can be obtained, and then the obtained multiple second sub-threshold values can be obtained.
- the minimum value of the threshold is used as the second threshold. It is also possible to obtain the second sub-threshold value according to each type of radar detection device, that is to say, for each type of radar detection device, one second sub-threshold value can be obtained, and then the obtained multiple second sub-threshold values The minimum value is used as the second threshold.
- a total of Second sub-threshold is based on the echo delay corresponding to the maximum detection distance of the two types of radar detection devices in the N-type radar detection device, and the radar signal sent by the two types of radar detection devices If the propagation delay is determined, or based on the echo delay corresponding to the maximum detection distance of a type of radar detection device in the N type radar detection device, and the propagation delay of the radar signal sent by this type of radar detection device, then , The second threshold can be The minimum value of the second sub-threshold.
- the first sub-threshold or the second sub-threshold value can be obtained only according to the different types of radar detection devices, and if the two radar detection devices are of the same category, it is not According to the two radar detection devices, the first sub-threshold or the second sub-threshold is obtained.
- the first sub-threshold value can be obtained according to each two types of radar detection devices, that is, for each two types of radar detection devices, a first sub-threshold value can be obtained, and then all The maximum value of the multiple first sub-thresholds obtained is used as the first threshold.
- a total of First sub-threshold is based on the echo delay corresponding to the maximum detection distance of the two types of radar detection devices in the N-type radar detection device, and the radar signal sent by the two types of radar detection devices If the propagation delay is determined, then the first threshold can be The maximum value of the first sub-threshold.
- the second sub-threshold value can be obtained according to each two types of radar detection devices, that is, for each two types of radar detection devices, a second sub-threshold value can be obtained, and then the obtained multiple second sub-threshold values can be obtained.
- the minimum value of the threshold is used as the second threshold. For example, according to the N-type radar detection device, a total of Second sub-threshold, Each of the second sub-thresholds is based on the echo delay corresponding to the maximum detection distance of the two types of radar detection devices in the N-type radar detection device, and the radar signal sent by the two types of radar detection devices If the propagation delay is determined, then the second threshold can be The minimum value of the second sub-threshold.
- N-type radar detection devices may all be radar detection devices that need to transmit radar signals, or in other words, they may all be radar detection devices that need to select a time domain range from multiple time domain ranges to transmit radar signals, or N-type radar detection devices Some types of radar detection devices in the device may not need to select a time domain range from multiple time domain ranges.
- the N type radar detection device may include all types of radar detection devices currently on the market. The embodiment of the present application does not limit what the N-type radar detection device includes.
- the first threshold is calculated based on the fourth radar detection device and the fifth radar detection device as an example. That is to say, the first threshold is the maximum value among the multiple first sub-threshold values, and the maximum value finally selected is calculated based on the fourth radar detection device and the fifth radar detection device, for example.
- the fourth radar detection device or the fifth radar detection device is, for example, the first radar detection device, or neither the fourth radar detection device nor the fifth radar detection device is the first radar detection device.
- the first threshold is the maximum value among the multiple first sub-thresholds
- the parameters of the first radar detection device such as the first echo delay and the first propagation delay
- the first threshold is based on at least one echo delay and Where the at least one propagation delay is determined, the at least one echo delay includes the first echo delay, and the at least one propagation delay includes the first propagation delay.
- the determination of the first sub-threshold or the second sub-threshold is also related to the position of the radar detection device.
- the radar detection device is a movable radar detection device, such as a vehicle-mounted radar detection device (such as a vehicle-mounted radar), and the radar detection device is a fixed-position radar detection device (such as a radar detection device installed on the RSU).
- the determined first sub-threshold or second sub-threshold may be different.
- the radar detection device is a movable radar detection device, such as a vehicle-mounted radar.
- the echo delay corresponding to the maximum detection distance of the fourth radar detection device the echo delay corresponding to the maximum detection distance of the fifth radar detection device, and the radar signal sent by the fourth radar detection device
- the maximum propagation delay (or the maximum propagation delay of the transmitted signal of the fourth radar detection device) and the maximum propagation delay of the radar signal sent by the fifth radar detection device (or the transmission signal of the fifth radar detection device)
- the maximum propagation delay of ) a first sub-threshold is determined.
- the final first threshold is the first sub-threshold determined by the fourth radar detection device and the fifth radar detection device
- the final second threshold is the first sub-threshold determined by the sixth radar detection device and the seventh radar detection device.
- Two sub thresholds are based on the echo delay corresponding to the maximum detection distance of the sixth radar detection device, the echo delay corresponding to the maximum detection distance of the seventh radar detection device, and the radar signal sent by the sixth radar detection device.
- the fourth radar detection device and the sixth radar detection device may be the same detection device, or may be different detection devices
- the fifth radar detection device and the seventh radar detection device may be the same detection device, or It is a different detection device.
- the calculation process is similar to the following process.
- the first threshold is the first sub-threshold obtained according to the fourth radar detection device and the fifth radar detection device
- the second threshold is the second sub-threshold obtained according to the fourth radar detection device and the fifth radar detection device.
- the threshold value is used to describe the program.
- the maximum propagation delay of the radar signal is determined according to the attributes or parameters of the current radar detection device itself.
- another radar signal will be received by the current radar detection device after a certain propagation delay. After the propagation delay, if the power of the interference signal is greater than the sensitivity of the receiver of the current radar detection device , The interference signal will interfere with the current radar detection device, and if the power of the interference signal is not greater than the sensitivity of the receiver of the current radar detection device, the interference signal will not interfere with the current radar detection device, and the interference signal will Is treated as noise.
- the propagation delay if the power of the interference signal is equal to the sensitivity of the current radar detection device receiver, then the distance between the radar detection device transmitting the interference signal and the current radar detection device is called the maximum tolerable interference distance , The propagation delay is called the maximum propagation delay.
- the echo delay corresponding to the maximum detection distance of the fourth radar detection device and the echo delay corresponding to the maximum detection distance of the fifth radar detection device may be the same or different; the difference between the radar signal sent by the fourth radar detection device The maximum propagation delay and the maximum propagation delay of the radar signal sent by the fifth radar detection device may be the same or different.
- the fourth radar detection device and the fifth radar detection device may be radar detection devices of the same type, or may also be radar detection devices of different types.
- the transmission time between the fourth radar detection device and the fifth radar detection device needs to be at least ⁇ max1 to ensure the two radars
- ⁇ max1 represents the echo delay corresponding to the maximum detection distance of the fourth radar detection device
- formula 2.1 can also be regarded as two formulas, for example, It can be considered as the first formula for determining the first threshold, It can be considered as the fifth formula for determining the second threshold.
- the formula for determining the first threshold and the formula for determining the second threshold can be combined into one formula, for example, formula 2.1, then the first threshold and the second threshold can be determined together; or, the formula for determining the first threshold and the formula for determining the second threshold
- the formula can also exist alone, and the first threshold and the second threshold can be determined separately.
- formula 2.1 Indicates the echo delay corresponding to the maximum detection distance of the fourth radar detection device, Indicates the echo delay corresponding to the maximum detection distance of the fifth radar detection device.
- the absolute value of the slope can represent the frequency change amount per unit time (or the frequency change range per unit time), so it can also be considered that a 1 represents the radar signal sent by the fourth radar detection device The amount of frequency change per unit time, a 2 represents the amount of frequency change per unit time of the radar signal sent by the fifth radar detection device.
- a 1 represents the slope of the radar signal sent by the fourth radar detection device
- a 2 represents the slope of the radar signal sent by the fifth radar detection device.
- a 1 in the embodiment of the present application may represent the absolute value of the slope, or may also represent the slope. If a 1 represents the slope, the value of a 1 may be positive or negative.
- a 2 can represent the absolute value of the slope, or it can also represent the slope. If a 2 represents the slope, the value of a 2 may be positive or negative.
- ⁇ t represents the absolute value of the difference in the L time domain any two of the time domain of the time domain starting position.
- T c represents the frequency sweep period of the fourth radar detection device.
- FIG. 18 is a schematic diagram of the time domain range of the fourth radar detection device and the time domain range of the fifth radar detection device determined according to the above method.
- the solid lines all indicate the signals of the fourth radar detection device
- the dashed lines all indicate the signals of the fifth radar detection device (except for the three vertical dotted lines)
- B indicates the sweep bandwidth of the fourth radar detection device.
- the signal sent by the fifth radar detection device must be at least later than the echo delay corresponding to the maximum detection distance of the fourth radar detection device (in Figure 18, the first solid line from left to right represents the fourth The radar detection device emits signals in a cycle.
- the second solid line from left to right represents the reflected signal of the transmitted signal, that is, the echo signal
- the third solid line from left to right represents that the transmitted signal has experienced the maximum Propagation delay The latter signal) and the maximum propagation delay of the radar signal sent by the fourth radar detection device, so that the transmitted signal of the fourth radar detection device will not be received by the fifth radar detection device as a received signal. Therefore,
- the transmission signal of the fifth radar detection device is The range of bandwidth B will not intersect the target echo observation range of the fourth radar detection device.
- the transmitted signal of the fourth radar detection device does not fall to the target of the fifth radar detection device within the range of bandwidth B Within the echo observation range. Therefore, Moreover, a 2 needs to meet the following constraints, and the above formula can have no restriction on the sweep period of the fifth radar detection device:
- formula 2.1 can be obtained. It can be seen in Figure 18 that the transmitted signals of the two radar detection devices will not fall within the target echo observation range of the other side, and will not cause interference to the other side. In addition, Fig. 18 is based on the signal of the fourth radar detection device. To make the signal of the fifth radar detection device meet the corresponding requirements so that the two radar detection devices will not interfere with each other, the formula 2.1 is applied to In Fig. 18, T c may be the frequency sweep period of the fourth radar detection device.
- the frequency sweep bandwidth of the fourth radar detection device is 250 MHz
- the frequency sweep period Tc is 27.8 ⁇ s
- the maximum detection distance is 250 m
- the corresponding maximum intermediate frequency is 15 MHz.
- the slope of the radar signal sent by the fifth radar detection device (for a radar detection device, the slope of the transmitted signal (that is, the transmitted radar signal), the slope of the reflected signal, and the slope of the signal after the transmitted signal undergoes a propagation delay The same) is 1.2 times the slope of the radar signal sent by the fourth radar detection device, the maximum detection distance of the fifth radar detection device is also 250m, and the maximum propagation delay of the signal between multiple radars is 2 ⁇ s (for example, the fourth radar detection device After the transmitted radar signal has propagated for 600 meters, the signal power reaching the receiver of the fifth radar detection device is -115dBm, which is equal to the receiver sensitivity of the fifth radar detection device, so the maximum propagation delay of the fourth radar detection device is 2 ⁇ s). Can be calculated according to the maximum detection distance of 250m
- FIG. 19 is a schematic diagram of an arrangement of the time domain where multiple radars are located.
- the thicker solid lines all represent the corresponding radar's transmit signal
- the dashed line represents the corresponding radar's reflected signal (echo signal)
- the thinner solid line indicates that the corresponding radar's transmit signal is experiencing propagation delay. After the signal.
- the smaller the distance between the time domain ranges the more time domain ranges can be arranged under the same sweep duration.
- the radar detection device and the time domain range may have a one-to-one correspondence. Therefore, in each embodiment of the present application, by taking the interval of the time domain range to the minimum value of the obtained range, more radar detection devices can be accommodated. .
- formula 2.2 can also be regarded as two formulas, for example, It can be considered as the second formula for determining the first threshold, It can be considered as the sixth formula for determining the second threshold.
- the formula for determining the first threshold and the formula for determining the second threshold can be combined into one formula, for example, formula 2.2, then the first threshold and the second threshold can be determined together; or, the formula for determining the first threshold and the formula for determining the second threshold
- the formula can also exist alone, and the first threshold and the second threshold can be determined separately.
- FIG. 20 is a schematic diagram of the time domain range of the fourth radar detection device and the time domain range of the fifth radar detection device determined according to the above method.
- the solid lines all indicate the signals of the fourth radar detection device
- the dashed lines all indicate the signals of the fifth radar detection device (except for the three vertical dotted lines)
- B indicates the sweep bandwidth of the fourth radar detection device.
- the time when the fifth radar detection device sends a signal needs to be at least later than the echo delay corresponding to the maximum detection distance of the fourth radar detection device (in Figure 20, the first solid line from left to right represents the fourth The radar detection device emits signals in a cycle.
- the second solid line from left to right represents the reflected signal of the transmitted signal, that is, the echo signal
- the third solid line from left to right represents that the transmitted signal has experienced the maximum Propagation delay The latter signal
- the maximum propagation delay of the radar signal sent by the fourth radar detection device so that the transmitted signal of the fourth radar detection device will not be received by the fifth radar detection device as a received signal. Therefore, And because the slope of the radar signal sent by the fourth radar detection device is the same as the slope of the radar signal sent by the fifth radar detection device, there is no need to consider the situation where the waveforms of the two radar detection devices will intersect. It is the formula 2.2. It can be seen in Figure 20 that the transmitted signals of the two radar detection devices will not fall within the target echo observation range of each other, and will not cause interference to each other.
- Fig. 20 is based on the signal of the fourth radar detection device.
- the formula 2.2 is applied to In Fig. 20, T c may be the frequency sweep period of the fourth radar detection device.
- the fourth radar detection device and the fifth radar detection device Take the fourth radar detection device and the fifth radar detection device as both a long range radar (LRR), and the parameters of the fourth radar detection device and the fifth radar detection device are the same as an example.
- the sweep bandwidth of the fourth LRR is 250MHz
- the sweep period Tc is 27.8 ⁇ s
- the maximum detection distance is 250m
- the corresponding maximum IF frequency is 15MHz
- the maximum propagation delay is 2 ⁇ s (for example, the radar signal of the fourth LRR passes through After 600 meters of propagation, the signal power reaching the fifth LRR receiver is -115 dBm, which is equal to the receiver sensitivity of the fifth LRR, so the maximum propagation delay of the fourth LRR is 2 ⁇ s).
- the parameters of the fourth LRR and the fifth LRR are the same, the above parameters correspond to the fourth LRR and also correspond to the fifth LRR. Can be calculated according to the maximum detection distance of 250m
- FIG. 19 for a schematic diagram of an arrangement of the time domain range where multiple LRRs are located.
- LRR can use a 1GHz bandwidth of 76-77GHz
- the sweep bandwidth of LRR is 250MHz
- 4 frequency domain resources that do not interfere with each other can be frequency-divided for use by LRR.
- these 4 frequency domain resources These are 76GHz ⁇ 76.25GHz, 76.25GHz ⁇ 76.50GHz, 76.50GHz ⁇ 76.70GHz, and 76.70GHz ⁇ 77GHz in FIG. 21, respectively.
- the formula 2.2-1 can also be regarded as two formulas.
- max( ⁇ max , ⁇ p ) ⁇ t can be regarded as the second formula for determining the first threshold
- ⁇ t ⁇ T c -max( ⁇ max , ⁇ p ) can be considered as the sixth formula for determining the second threshold.
- ⁇ max represents the echo delay corresponding to the maximum detection distance of the fourth radar detection device
- ⁇ p represents the radar sent by the fourth radar detection device
- the maximum propagation delay of the signal also represents the maximum propagation delay of the radar signal sent by the fifth radar detection device. It can be seen that if the corresponding parameters of the two radar detection devices are the same, it is only necessary to calculate the first threshold or the second threshold according to the parameters of one of the radar detection devices.
- the formula for determining the first threshold and the formula for determining the second threshold can be combined into one formula, for example, formula 2.2-1, then the first threshold and the second threshold can be determined together; or, the formula for determining the first threshold and the formula for determining the second threshold
- the threshold formula can also exist separately, and the first threshold and the second threshold can be determined separately.
- the sweep bandwidth of the fourth radar detection device is 250MHz
- the sweep period Tc is 27.8 ⁇ s
- the maximum detection distance is 250m
- the corresponding maximum intermediate frequency is 15MHz
- the maximum propagation delay of signals between multiple radars is 2 ⁇ s (for example, the first After the radar signal transmitted by the fourth radar detection device has propagated for 600 meters, the signal power reaching the receiver of the fifth radar detection device is -115dBm, which is equal to the receiver sensitivity of the fifth radar detection device, so the maximum of the fourth radar detection device The propagation delay is 2 ⁇ s).
- the above formula 2.1, formula 2.2, and formula 2.2-1 do not consider the synchronization error between radar detection devices, and different radar detection devices may have inconsistencies in their understanding of time. For example, the fourth radar detection device thinks that a moment is 10:00:00, and the fifth radar detection device may think that the time is 10:00:02, so there will be synchronization errors between the two radar detection devices. If the synchronization error between the two radar detection devices is considered, the method for determining the first threshold will be different. For example, the first threshold may be determined based on at least one propagation delay, at least one echo delay, and first information, and the second sub-threshold may be determined based on at least one propagation delay, at least one echo delay, and first information. Threshold.
- the fourth radar detection device and the fifth radar detection device are taken as examples, it can be based on the echo delay corresponding to the maximum detection distance of the fourth radar detection device and the echo delay corresponding to the maximum detection distance of the fifth radar detection device.
- the maximum propagation delay of the radar signal sent by the fourth radar detection device, the maximum propagation delay of the radar signal sent by the fifth radar detection device, and the first information determine the first threshold.
- the fourth radar detection device and the fifth radar detection device are taken as examples, it can be based on the echo delay corresponding to the maximum detection distance of the fourth radar detection device and the echo corresponding to the maximum detection distance of the fifth radar detection device.
- the wave delay, the maximum propagation delay of the radar signal sent by the fourth radar detection device, the maximum propagation delay of the radar signal sent by the fifth radar detection device, and the first information determine the second sub-threshold.
- the first information may include a time margin, or a synchronization error between two radar detection devices, or, a time margin and a sum of synchronization errors between two radar detection devices.
- the first information can include the time margin, or, include the synchronization error between the fourth radar detection device and the fifth radar detection device, or, Including the time margin and the sum of the synchronization error between the fourth radar detection device and the fifth radar detection device.
- the synchronization error may be different, and the time margin may be different or the same.
- the first threshold can be determined according to the third formula
- the third formula can be
- the second threshold can be determined according to the seventh formula, which can be Comprehensively available:
- ⁇ s represents the synchronization error between the two radar detection devices. If the fourth radar detection device and the fifth radar detection device participate in the calculation, ⁇ s represents the synchronization error between the fourth radar detection device and the fifth radar detection device .
- ⁇ represents time margin.
- the formula for determining the first threshold and the formula for determining the second threshold can be combined into one formula, for example, formula 2.3, then the first threshold and the second threshold can be determined together; or, the formula for determining the first threshold and the formula for determining the second threshold
- the threshold formula can also exist separately, and the first threshold and the second threshold can be determined separately.
- the sweep bandwidth of the fourth LRR is 250MHz
- the sweep period Tc is 27.8us
- the maximum detection distance is 250m
- the corresponding maximum intermediate frequency is 15MHz.
- the slope of the radar signal sent by the fifth LRR (for a radar detection device, the slope of the transmitted signal, the slope of the reflected signal, and the slope of the transmitted signal after the propagation delay are the same) is the radar signal sent by the fourth LRR
- the maximum detection range of the fifth LRR is also 250m
- the maximum propagation delay of the radar signal sent by the fourth LRR is 2 ⁇ s
- the maximum propagation delay of the radar signal sent by the fifth LRR is also 2 ⁇ s (for example, the first After the radar signal of the four LRR propagates for 600 meters, the signal power reaching the fifth LRR receiver is -115dBm, which is equal to the receiver sensitivity of the fifth LRR, so the maximum propagation delay of the fourth LRR is 2 ⁇ s).
- GPS global positioning system
- the transmission can be made within the L time domain ranges.
- the absolute value of the difference between the time domain start positions of any two delay ranges in the L time domain ranges is greater than or equal to 9.7 ⁇ s and less than or equal to 20.8 ⁇ s, the transmission can be made within the L time domain ranges.
- the radar detection that does not interfere with each other can be supported.
- the number of devices is Regarding an arrangement diagram of the time domain range where multiple LRRs are located, continue to refer to FIG. 19.
- Formula 2.4 can also be regarded as two formulas, for example, It can be considered as the fourth formula for determining the first threshold, It can be considered as the eighth formula for determining the second threshold.
- the formula for determining the first threshold and the formula for determining the second threshold can be combined into one formula, for example, formula 2.4, then the first threshold and the second threshold can be determined together; or, the formula for determining the first threshold and the formula for determining the second threshold
- the threshold formula can also exist alone, and the first threshold and the second threshold can be determined separately.
- the sweep bandwidth of LRR is 250MHz
- the sweep period Tc is 27.8 ⁇ s
- the maximum detection distance is 250m
- the corresponding maximum intermediate frequency is 15MHz, which is the maximum propagation delay sum of the radar signal sent by the fourth radar detection device
- the maximum propagation delay of the radar signal sent by the fifth radar detection device is 2 ⁇ s (for example, after the radar signal of the fourth radar detection device has propagated 600 meters, the signal power reaching the receiver of the fifth radar detection device is -115dBm, It is equal to the receiver sensitivity of the fifth detection device, so the maximum propagation delay of the fourth radar detection device is 2 ⁇ s). Because the parameters of the fourth radar detection device are the same as those of the fifth radar detection device, the above parameters correspond to the fourth radar detection device and also correspond to the fifth radar detection device. Can be calculated according to the maximum detection distance of 250m
- the radar can be transmitted within the L time domain ranges. There is no interference between any two radar detection devices of the signal.
- the absolute value of the difference between the time domain starting positions of any two time delay ranges in the L time domain ranges can be made equal to the first threshold, for example, equal to 5 ⁇ s, so that the number of radar detection devices that do not interfere with each other can be made Reach the maximum and improve the utilization of time domain resources.
- formula 2.4 On the basis of formula 2.4, if the echo delay corresponding to the maximum detection distance of the fourth radar detection device is equal to the echo delay corresponding to the maximum detection distance of the fifth radar detection device, and the radar signal sent by the fourth radar detection device The maximum propagation delay of is equal to the maximum propagation delay of the radar signal sent by the fifth radar detection device.
- the fourth radar detection device and the fifth radar detection device are the same type of radar detection device. Then, formula 2.4 can also be transformed into:
- the formula 2.4-1 can also be regarded as two formulas, for example, max( ⁇ max , ⁇ p )+ ⁇ t can be regarded as the second formula for determining the first threshold, ⁇ t ⁇ T c- max( ⁇ max , ⁇ p )- ⁇ can be considered as the sixth formula for determining the second threshold.
- the formula for determining the first threshold and the formula for determining the second threshold can be combined into one formula, for example, formula 2.4-1, then the first threshold and the second threshold can be determined together; or, the formula for determining the first threshold and the formula for determining the second threshold
- the threshold formula can also exist separately, and the first threshold and the second threshold can be determined separately.
- the sweep bandwidth of the fourth radar detection device is 250MHz
- the sweep period Tc is 27.8 ⁇ s
- the maximum detection distance is 250m
- the corresponding maximum intermediate frequency is 15MHz
- the maximum propagation delay of signals between multiple radars is 2 ⁇ s (for example, the first After the radar signal transmitted by the fourth radar detection device has propagated for 600 meters, the signal power reaching the receiver of the fifth radar detection device is -115dBm, which is equal to the receiver sensitivity of the fifth radar detection device, so the maximum of the fourth radar detection device The propagation delay is 2 ⁇ s).
- the radar can be transmitted within the L time domain ranges. There is no interference between any two radar detection devices of the signal.
- the absolute value of the difference between the time domain starting positions of any two time delay ranges in the L time domain ranges can be made equal to the first threshold, for example, equal to 5 ⁇ s, so that the number of radar detection devices that do not interfere with each other can be made Reach the maximum and improve the utilization of time domain resources.
- the radar detection device is a movable radar detection device.
- the following describes the case where the radar detection device is not movable.
- the position of the radar detection device is fixed.
- the radar detection device is fixed on the RSU, or on the base station, or on other equipment.
- the radar detection device can also be deployed independently, but the location is fixed.
- the first threshold value (or the first sub-threshold value) can be determined according to at least one propagation delay and at least one echo time delay, or according to at least one propagation delay and at least one echo time delay. Delay to determine the second threshold (or rather, determine the second sub-threshold).
- the fourth radar detection device and the fifth radar detection device participating in the calculation is based on the echo delay corresponding to the maximum detection distance of the fourth radar detection device and the echo delay corresponding to the maximum detection distance of the fifth radar detection device.
- the first threshold is determined by the propagation delay of the radar signal sent by the fourth radar detection device and the propagation delay of the radar signal sent by the fifth radar detection device.
- the sixth radar detection device and the seventh radar detection device participating in the calculation it is based on the echo delay corresponding to the maximum detection distance of the sixth radar detection device and the echo corresponding to the maximum detection distance of the seventh radar detection device.
- the wave delay, the propagation delay of the radar signal sent by the sixth radar detection device, and the propagation delay of the radar signal sent by the seventh radar detection device determine the second threshold.
- the echo delay corresponding to the maximum detection distance of the fourth radar detection device and the echo delay corresponding to the maximum detection distance of the fifth radar detection device may be the same or different; the difference between the radar signal sent by the fourth radar detection device
- the propagation delay and the propagation delay of the radar signal sent by the fifth radar detection device may be the same or different.
- the propagation delay of the radar signal sent by the fourth radar detection device refers to the time when the radar signal sent by the fourth radar detection device reaches the fifth radar detection device.
- Propagation delay the propagation delay of the radar signal sent by the fifth radar detection device refers to the propagation delay of the radar signal sent by the fifth radar detection device to the fourth radar detection device.
- the echo delay corresponding to the maximum detection distance of the sixth radar detection device and the echo delay corresponding to the maximum detection distance of the seventh radar detection device may be the same or different; the propagation time of the radar signal sent by the sixth radar detection device The delay and the propagation delay of the radar signal sent by the seventh radar detection device may be the same or different.
- the propagation delay of the radar signal sent by the sixth radar detection device refers to the time when the radar signal sent by the sixth radar detection device reaches the seventh radar detection device.
- Propagation delay the propagation delay of the radar signal sent by the seventh radar detection device refers to the propagation delay of the radar signal sent by the seventh radar detection device to the sixth radar detection device.
- the embodiment of the present application sets the difference between the time domain starting positions of any two time domain ranges in the L time domain ranges When the absolute value of, it is also necessary to consider Article (1), Article (2) and Article (3) mentioned in the first point.
- formula 2.5 can also be regarded as two formulas, for example, It can be considered as the first formula for determining the first threshold, It can be considered as the fifth formula for determining the second threshold. Based on the first article, the first formula can be or The fifth formula can be or
- the formula for determining the first threshold and the formula for determining the second threshold can be combined into one formula, such as formula 2.5, then the first threshold and the second threshold can be determined together; or, the formula for determining the first threshold and the formula for determining the second threshold
- the formula can also exist alone, and the first threshold and the second threshold can be determined separately.
- FIG. 22 is a schematic diagram of the time domain range of the fourth radar detection device and the time domain range of the fifth radar detection device determined according to the above method.
- the solid lines all indicate the signals of the fourth radar detection device
- the dashed lines all indicate the signals of the fifth radar detection device (except for the three vertical dashed lines)
- B indicates the sweep bandwidth of the fourth radar detection device.
- the time when the fifth radar detection device sends out the radar signal must be at least later than the echo delay corresponding to the maximum detection distance of the fourth radar detection device (in Figure 22, the first solid line from left to right represents the first Four radar detection devices transmit signals in one cycle.
- the second solid line from left to right represents the reflected signal of the transmitted signal, that is, the echo signal.
- the third solid line from left to right represents the transmitted signal experience Propagation delay The latter signal) and the propagation time delay of the radar signal sent by the fourth radar detection device, so that the transmitted signal of the fourth radar detection device will not be received by the fifth radar detection device as a received signal. Therefore,
- the transmission signal of the fifth radar detection device is The range of bandwidth B will not intersect the target echo observation range of the fourth radar detection device, of course, it must be ensured that the transmitted signal of the fourth radar detection device does not fall to the target of the fifth radar detection device within the range of bandwidth B Within the echo observation range. Therefore, Moreover, a 2 needs to meet the following constraints, and the above formula can have no restriction on the sweep period of the fifth radar detection device:
- formula 2.5 can be obtained. It can be seen in Figure 22 that the transmitted signals of the two radar detection devices are not within the observation range of the other's target echo, and will not cause interference to the other. In addition, Fig. 22 is based on the signal of the fourth radar detection device. To make the radar signal of the fifth radar detection device meet the corresponding requirements so that the two radar detection devices will not interfere with each other, the formula 2.5 is applied In Fig. 22, T c may be the transmission period of the fourth radar detection device.
- the fourth radar detection device and the fifth radar detection device both as radars set on the RSU can be called RSU radar 1 and RSU radar 2, respectively.
- the RSU radar sweep bandwidth of 250MHz 1
- sweep period T c is 27.8 ⁇ s
- the maximum detection distance of 250m corresponding to the maximum IF frequency of 15MHz.
- the slope of the radar signal sent by RSU radar 2 is 1.2 times that of the radar signal sent by RSU radar 1.
- the maximum detection range of RSU radar 2 is 200m
- the sweep bandwidth is 250MHz
- the sweep period T c is 27.8 ⁇ s.
- the maximum IF frequency is 15MHz.
- RSU radar 1 and RSU radar 2 are 300m apart, we can get It can be calculated according to the maximum detection distance of the fourth radar detection device of 250m And, it can be calculated based on the maximum detection distance of the fifth radar detection device of 200m
- formula 2.6 can also be regarded as two formulas, for example, It can be considered as the second formula for determining the first threshold, It can be considered as the sixth formula for determining the second threshold. Based on the first one, the second formula can be or The sixth formula can be or
- the formula for determining the first threshold and the formula for determining the second threshold can be combined into one formula, for example, formula 2.6, then the first threshold and the second threshold can be determined together; or, the formula for determining the first threshold and the formula for determining the second threshold
- the formula can also exist alone, and the first threshold and the second threshold can be determined separately.
- FIG. 23 is a schematic diagram of the time domain range of the fourth radar detection device and the time domain range of the fifth radar detection device determined according to the above method.
- the solid lines all indicate the signals of the fourth radar detection device
- the dashed lines all indicate the signals of the fifth radar detection device (except for the three vertical dotted lines)
- B indicates the sweep bandwidth of the fourth radar detection device, from left to right
- the first solid line on the right represents the transmitted signal of the fourth radar detection device in one cycle
- the second solid line from left to right represents that the transmitted signal has experienced propagation delay.
- the third solid line from left to right represents the reflected signal of the transmitted signal, that is, the echo signal.
- the transmission signal of the fourth radar detection device is required and the transmission signal undergoes propagation delay
- the latter signal does not fall within the target echo observation range of the fifth radar detection device, so there is,
- the slope of the radar signal sent by the fourth radar detection device is the same as the slope of the radar signal sent by the fifth radar detection device, there is no need to consider the situation where the waveforms of the two radar detection devices will intersect. It is formula 2.6. It can be seen in Figure 23 that the transmitted signals of the two radar detection devices will not fall within the target echo observation range of each other, and will not cause interference to each other.
- Fig. 23 is based on the radar signal of the fourth radar detection device.
- T c may be the transmission period of the fourth radar detection device.
- the fourth radar detection device and the fifth radar detection device as an example of radars set on the RSU, which can be called RSU radar 1 and RSU radar 2, respectively.
- the slope of the radar signal sent by RSU radar 1 is the same as that sent by RSU radar 2.
- the slope of the radar signal is the same.
- the sweep bandwidth of the RSU radar 1 is 250 MHz
- the sweep period T c is 27.8 ⁇ s
- the maximum detection distance is 250 m
- the corresponding maximum intermediate frequency is 15 MHz.
- RSU maximum detection distance of the radar 2 250m
- sweep period T c is 27.8 ⁇ s, corresponding to the maximum IF frequency of 15MHz.
- RSU radar 1 and RSU radar 2 are 300m apart, we can get Can be calculated according to the maximum detection distance of 250m
- the formula 2.6-1 can also be regarded as two formulas, for example, max( ⁇ p , ⁇ max - ⁇ p ) ⁇ t can be regarded as the second formula to determine the first threshold, ⁇ t ⁇ T c -max( ⁇ p , ⁇ max - ⁇ p ) can be considered as the sixth formula for determining the second threshold.
- the second formula can be or Or max( ⁇ p , ⁇ max - ⁇ p ) ⁇ t
- the sixth formula can be or or or or or or or
- the formula for determining the first threshold and the formula for determining the second threshold can be combined into one formula, for example, formula 2.6-1, then the first threshold and the second threshold can be determined together; or, the formula for determining the first threshold and the formula for determining the second threshold
- the threshold formula can also exist separately, and the first threshold and the second threshold can be determined separately.
- the fourth radar detection device and the fifth radar detection device both as radars set on the RSU can be called RSU radar 1 and RSU radar 2, respectively.
- the sweep bandwidth of the RSU radar 1 is 250 MHz
- the sweep period T c is 27.8 ⁇ s
- the maximum detection distance is 250 m
- the corresponding maximum intermediate frequency is 15 MHz.
- ⁇ p 1 ⁇ s can be obtained.
- ⁇ max 250 ⁇ 2/speed of light ⁇ 1.67 ⁇ s can be calculated.
- formula 2.6 and formula 2.6-1 can be considered to be applicable to the distance between the fourth radar detection device and the fifth radar detection device being less than with The larger value in the corresponding to the speed of light travel distance.
- the propagation time is with
- a distance can be calculated, which is with The larger value in the corresponding light speed travel distance. If the slope of the radar signal sent by the fourth radar detection device is the same as the slope of the radar signal sent by the fifth radar detection device, and the distance between the fourth radar detection device and the fifth radar detection device is less than this distance, the formula can be used 2.6 or formula 2.6-1. And if the distance between the fourth radar detection device and the fifth radar detection device is greater than or equal to this distance, there may be other ways to determine ⁇ t .
- M can be set to 0, then the fourth radar detection device and the fifth radar detection device send signals at the same time.
- FIG. 24 is a schematic diagram of the time domain range of the fourth radar detection device and the time domain range of the fifth radar detection device determined according to the above method.
- the first solid line from left to right represents the emission signal of the fourth radar detection device in one cycle, and it also represents the emission signal of the fifth radar detection device in one cycle
- the second solid line from left to right The line represents the reflection signal of the transmitted signal of the fourth radar detection device, that is, the echo signal
- the first dashed line from left to right represents the reflection signal of the transmission signal of the fifth radar detection device, that is, the echo signal.
- the third solid line to the right indicates that the transmitted signal of the fourth radar detection device has experienced propagation delay After the signal
- the second dashed line from left to right indicates that the transmitted signal of the fifth radar detection device has experienced propagation delay After the signal. It can be seen that the transmitted signals of the two radar detection devices will not fall within the target echo observation range of the other party, and will not cause interference to the other party.
- the above formula 2.5, formula 2.6 or formula 2.6-1 does not consider the first information. If the first information is considered, the method for determining the first threshold will be different.
- the first threshold may be determined based on at least one echo delay, at least one propagation delay, and first information.
- the second threshold can be determined based on at least one echo delay, at least one propagation delay, and the first information.
- the echo delay corresponding to the maximum detection distance of the first radar detection device and the echo corresponding to the maximum detection distance of the second radar detection device can be used.
- the time delay, the propagation time delay of the radar signal sent by the first radar detection device, the propagation time delay of the radar signal sent by the second radar detection device, and the first information determine the first threshold.
- the echo delay corresponding to the maximum detection distance of the first radar detection device and the maximum detection distance of the second radar detection device can correspond to The second threshold is determined by the echo delay of the echo delay, the propagation delay of the radar signal sent by the first radar detection device, the propagation delay of the radar signal sent by the second radar detection device, and the first information.
- the first threshold can be determined according to the third formula
- the third formula can be
- the second threshold can be determined according to the seventh formula, which can be Comprehensively available:
- the formula for determining the first threshold and the formula for determining the second threshold can be combined into one formula, for example, formula 2.7, then the first threshold and the second threshold can be determined together; or, the formula for determining the first threshold and the formula for determining the second threshold
- the threshold formula can also exist separately, and the first threshold and the second threshold can be determined separately.
- the third formula is or The seventh formula is or
- the slope of the radar signal sent by RSU radar 2 is that sent by RSU radar 1.
- the slope of the radar signal is 1.2 times.
- sweep period T c is 27.8 ⁇ s
- the maximum detection distance of 250m corresponding to the maximum IF frequency of 15MHz.
- the slope of the radar signal sent by RSU radar 2 is 1.2 times the slope of the radar signal sent by RSU radar 1.
- the maximum detection range of RSU radar 2 is 200 m
- the sweep bandwidth is 250 MHz
- the sweep period T c is 27.8 ⁇ s.
- the maximum intermediate frequency is 15MHz.
- the distance between RSU radar 1 and RSU radar 2 is 300m
- we can get According to the maximum detection range of RSU radar 1 is 250m, it can be calculated And, it can be calculated according to the maximum detection range of RSU radar 2 of 200m
- the synchronization error ⁇ s between RSU radar 1 and RSU radar 1 can refer to the GPS timing error, such as 2 ⁇ s. If the first information includes the synchronization error between RSU radar 1 and RSU radar 2, and does not include the time margin, with in equation 2.7 can be obtained 7.7 ⁇ s ⁇ t ⁇ 24.7 ⁇ s.
- the radar can be transmitted within the L time domain ranges. There is no interference between any two radar detection devices of the signal.
- the absolute value of the difference between the time domain starting positions of any two time domain ranges in the L time domain ranges can be made equal to the first threshold, for example, equal to 8.7 ⁇ s, so that the radar detection devices that do not interfere with each other can be The number reaches the maximum, which improves the utilization of time domain resources.
- Equation 2.8 can also be regarded as two formulas, for example, It can be considered as the fourth formula for determining the first threshold, It can be considered as the eighth formula for determining the second threshold.
- the formula for determining the first threshold and the formula for determining the second threshold can be combined into one formula, for example, formula 2.8, then the first threshold and the second threshold can be determined together; or, the formula for determining the first threshold and the formula for determining the second threshold
- the threshold formula can also exist separately, and the first threshold and the second threshold can be determined separately.
- the fourth formula can be or The eighth formula can be or
- the slope of the radar signal sent by RSU radar 1 is the same as that sent by RSU radar 2.
- the slopes of the radar signals are equal.
- the sweep bandwidth of the RSU radar 1 is 250 MHz
- the sweep period T c is 27.8 ⁇ s
- the maximum detection distance is 250 m
- the corresponding maximum intermediate frequency is 15 MHz.
- RSU maximum detection distance of the radar 2 250m
- sweep period T c is 27.8 ⁇ s, corresponding to the maximum IF frequency of 15MHz.
- RSU radar 1 and RSU radar 2 are 300m apart, we can get Can be calculated according to the maximum detection distance of 250m
- Incorporating into formula 2.8 can be obtained, max(1,1.67-1) ⁇ t ⁇ 27.8-max(1,1.67-1), that is, 1 ⁇ s ⁇ t ⁇ 26.8 ⁇ s.
- the synchronization error ⁇ s between RSU radar 1 and RSU radar 2 can refer to the GPS timing error, such as 2 ⁇ s. If the first information includes the synchronization error between RSU radar 1 and RSU radar 2, and does not include the time margin, with in equation 2.8 can be obtained 3 ⁇ s ⁇ t ⁇ 24.8 ⁇ s.
- ⁇ can be a pre-defined or pre-configured constant, which represents the time jitter caused by non-ideal factors of the RSU radar itself.
- ⁇ 1 ⁇ s
- the first information includes the time margin and the difference between RSU radar 1 and RSU radar 2.
- the formula 2.8 may be obtained, 4 ⁇ s ⁇ t ⁇ 23.8 ⁇ s.
- the absolute value of the difference between the time domain starting positions of any two time domain ranges in the L time domain ranges is greater than or equal to 4 ⁇ s and less than or equal to 23.8 ⁇ s, the radar can be transmitted within the L time domain ranges. There is no interference between any two radar detection devices of the signal.
- the absolute value of the difference between the time-domain starting positions of any two time-domain ranges in the L time-domain ranges can be made equal to the first threshold, for example, equal to 4 ⁇ s, so that the number of radar detection devices that do not interfere with each other can be made Reach the maximum and improve the utilization of time domain resources.
- the absolute value of the difference between the start positions of any two time domains in the L time domains is 4 ⁇ s, then under the sweep period of 27.8 ⁇ s, a radar detection device that does not interfere with each other can be supported.
- the quantity is Regarding an arrangement diagram of the time domain range where multiple LRRs are located, continue to refer to FIG. 19.
- the fourth radar detection device and the fifth radar detection device If the distance between is less than this distance, you can use Equation 2.8. And if the distance between the fourth radar detection device and the fifth radar detection device is greater than or equal to this distance, there may be other ways to determine ⁇ t .
- M can be set to 0, then the fourth radar detection device and the fifth radar detection device send signals at the same time.
- formula 2.8 On the basis of formula 2.8, if the echo delay corresponding to the maximum detection distance of the fourth radar detection device is equal to the echo delay corresponding to the maximum detection distance of the fifth radar detection device, and the radar signal sent by the fourth radar detection device The maximum propagation delay of is equal to the maximum propagation delay of the radar signal sent by the fifth radar detection device.
- the fourth radar detection device and the fifth radar detection device are the same type of radar detection device. Then, formula 2.8 can be transformed into:
- Formula 2.8-1 can also be regarded as two formulas, for example, It can be considered as the fourth formula for determining the first threshold, It can be considered as the eighth formula for determining the second threshold.
- the formula for determining the first threshold and the formula for determining the second threshold can be combined into one formula, for example, formula 2.8-1, then the first threshold and the second threshold can be determined together; or, the formula for determining the first threshold and the determination
- the formula for the second threshold may also exist alone, and the first threshold and the second threshold may be determined separately.
- the fourth formula can be or or The eighth formula can be or or
- the fourth radar detection device and the fifth radar detection device both as radars set on the RSU can be called RSU radar 1 and RSU radar 2, respectively.
- sweep period T c is 27.8 ⁇ s
- the maximum detection distance of 250m corresponding to the maximum IF frequency of 15MHz.
- Incorporating the formula 2.8-1 can be obtained, max(1,1.67-1) ⁇ t ⁇ 27.8-max(1,1.67-1), that is, 1 ⁇ s ⁇ t ⁇ 26.8 ⁇ s.
- the synchronization error ⁇ s between RSU radar 1 and RSU radar 2 can refer to the GPS timing error, such as 2 ⁇ s. If the first information includes the synchronization error between RSU radar 1 and RSU radar 2, and does not include the time margin, with into equation 2.8-1 can be obtained 3 ⁇ s ⁇ t ⁇ 24.8 ⁇ s.
- ⁇ can be a pre-defined or pre-configured constant, which represents the time jitter caused by non-ideal factors of the RSU radar itself.
- ⁇ 1 ⁇ s
- the first information includes the time margin and the difference between RSU radar 1 and RSU radar 2.
- synchronization error between, into the formula is 2.8-1 can be obtained, 4 ⁇ s ⁇ t ⁇ 23.8 ⁇ s.
- the radar can be transmitted within the L time domain ranges. There is no interference between any two radar detection devices of the signal.
- the absolute value of the difference between the time-domain starting positions of any two time-domain ranges in the L time-domain ranges can be made equal to the first threshold, for example, equal to 4 ⁇ s, so that the number of radar detection devices that do not interfere with each other can be made Reach the maximum and improve the utilization of time domain resources.
- the absolute value of the difference between the start positions of any two time domains in the L time domains is 4 ⁇ s, then under the sweep period of 27.8 ⁇ s, a radar detection device that does not interfere with each other can be supported.
- the quantity is Regarding an arrangement diagram of the time domain range where multiple LRRs are located, continue to refer to FIG. 19.
- the final first threshold is the first sub-threshold calculated based on the fourth radar detection device and the fifth radar detection device
- the second threshold is calculated based on the sixth radar detection device and the seventh radar detection device. The second sub-threshold.
- Time delay (or the maximum propagation delay of the transmitted signal of the fourth radar detection device) and the maximum propagation delay of the radar signal transmitted by the fifth radar detection device (or the maximum propagation delay of the transmitted signal of the fifth radar detection device) Propagation delay), determine a first sub-threshold, the first sub-threshold is the maximum value of the multiple first sub-thresholds, that is, the final first threshold.
- a second sub-threshold value is determined, and the second sub-threshold value is the maximum value of the multiple second sub-threshold values, that is, the final second threshold value.
- the second sub-threshold value is calculated based on the fourth radar detection device and the fifth radar detection device. If the second sub-threshold value is calculated based on the sixth radar detection device and the seventh radar detection device, Sub-threshold (which will eventually be used as the second threshold), then the calculation formula can be the same as the above formula. For simplicity, when the second sub-threshold is calculated according to the radar detection device and the seventh radar detection device, the above-mentioned use can also be used. Each letter in the formula for calculating the second sub-threshold value represents a corresponding parameter, which is equivalent to that the same letter may be used to represent different parameters in the embodiment of the present application.
- any one of formula 2.1 to formula 2.8 can be calculated according to the corresponding radar detection device only by substituting the parameters of the corresponding radar detection device.
- the parameters of the fourth radar detection device and the fifth radar detection device are substituted in formula 2.1 to formula 2.8, and the parameters of the fourth radar detection device and the fifth radar detection device may not be substituted.
- the parameters are substituted into the parameters of the sixth radar detection device and the seventh radar detection device, so that the first sub-threshold value or the second sub-threshold value is calculated according to the sixth radar detection device and the seventh radar detection device.
- the fourth radar detection device and the sixth radar detection device may be the same detection device, or they may be different detection devices; the fifth radar detection device and the seventh radar detection device may be the same detection device, or they may be different The detection device.
- radar detection device 1 there are radar detection device 1, radar detection device 2, and radar detection device 3.
- the distance between radar detection device 1 and radar detection device 2 is 300m
- the distance between radar detection device 1 and radar detection device 3 is 400m
- the distance between radar detection device 2 and radar detection device is 400m.
- 3 are 500 m apart, and the slope of the radar signal sent by the radar detection device 1, the slope of the radar signal sent by the radar detection device 2, and the slope of the radar signal sent by the radar detection device 3 are the same.
- the absolute value of the difference between the time domain range of the radar detection device 1 and the time domain starting position of the time domain range of the radar detection device 2 is in the range of 1 ⁇ s ⁇ ⁇ t ⁇ range difference absolute time domain starting position of the domain-wide time 26.8 ⁇ s
- time domain radar detection means 1 and the radar detection means 3 is 1.3 ⁇ s ⁇ t ⁇ 26.5 ⁇ s
- the radar detection means 2 the absolute value of the difference time-domain range domain starting position of the radar range of the time domain detecting means 3 is 1.67 ⁇ s ⁇ t ⁇ 26.1 ⁇ s, then, on the intersection of the three ranges (i.e.
- the time of any two time domain ranges in the L time domain ranges can be obtained the absolute value of the difference domain starting position range of 1.67 ⁇ s ⁇ t ⁇ 26.1 ⁇ s.
- a radar detection device can calculate ⁇ t to determine L time domain ranges, and then send the information of the L time domain ranges to other radar detection devices. In this way, the radar detection device selects the corresponding time domain range from the L time domain ranges to send the radar signal.
- the L time domain ranges can also be specified through an agreement, for example, the agreement specifies L time domain ranges and ⁇ t , so that the radar detection device selects the corresponding time domain range from the L time domain ranges to send the radar signal OK.
- the L time domain ranges can also be pre-configured in the radar detection device. For example, the information and ⁇ t of the L time domain ranges are pre-configured in the radar detection device. In this way, the radar detection device selects from the L time domain ranges. The radar signal can be sent in the corresponding time domain range.
- the first threshold and the second threshold can be calculated by the method provided in the embodiments of the present application, so that ⁇ t can be determined according to the first and second thresholds; or, it can be just provided by the embodiments of the present application.
- the method of calculating a first threshold and the second threshold value may be calculated by other means, and then determines ⁇ t according to a first threshold and the second threshold value, the method for calculating the second threshold value is not restricted;
- the present application may only The method provided in the embodiment calculates the second threshold value, and the first threshold value can be calculated in other ways, and then ⁇ t is determined according to the first threshold value and the second threshold value, and there is no restriction on the calculation method of the first threshold value.
- the first radar detection device sends a first radar signal within the first time domain range.
- the first radar detection device can send the first radar signal within the first time domain range, and the first radar signal can be reflected back after reaching the target object, so that the first radar device receives the reflected signal,
- the first radar device mixes the reflected signal and the local oscillator signal to obtain an intermediate frequency signal, so that one or more of the information such as the position, speed or angle of the target object can be determined based on the intermediate frequency signal.
- the second radar detection device can select a second time domain range from the L time domain ranges to send the second radar signal.
- different radar detection devices can select different time domain ranges to send radar signals.
- the first time domain range and the second time domain range may or may not have an intersection. If the first time domain range and the second time domain range have an intersection, then the time domain of the first time domain range and the second time domain range
- the absolute value of the difference between the starting positions may be ⁇ t calculated in S1701. Therefore, through the method provided in the embodiments of the present application, it can be ensured that the mutual interference area of the radar detection device disappears, and the problem of false alarms or platform interference can be avoided.
- the present embodiment may also make application ⁇ t in the range of the minimum value of the calculated, so that ⁇ t is equal to a first threshold value, then in the same time domain resource is available, it can be supported such noninterfering
- the number of radar detection devices is the largest, which greatly increases the utilization of time domain resources.
- each device such as the first radar detection device, includes a hardware structure and/or software module corresponding to each function.
- the embodiments of the present application can be implemented in the form of hardware or a combination of hardware and computer software. Whether a certain function is executed by hardware or computer software-driven hardware depends on the specific application and design constraint conditions of the technical solution. Professionals and technicians can use different methods for each specific application to implement the described functions, but such implementation should not be considered beyond the scope of the embodiments of the present application.
- the embodiment of the present application may divide the functional modules of the first radar detection device.
- each functional module may be divided corresponding to each function, or two or more functions may be integrated into one processing module.
- the above-mentioned integrated modules can be implemented in the form of hardware or software functional modules. It should be noted that the division of modules in the embodiments of the present application is illustrative, and is only a logical function division, and there may be other division methods in actual implementation.
- FIG. 25 shows a possible schematic diagram of the structure of the first radar detection device involved in the foregoing embodiment of the present application.
- the first radar detection device 25 may include a processing unit 2501 and a transceiver unit 2502.
- the processing unit 2501 may be used to perform all the operations performed by the first radar detection device in the embodiment shown in FIG. 17A except for the transceiving operation, such as S1701, and/or to support the technology described herein Other processes.
- the transceiving unit 2502 can be used to perform all the transceiving operations performed by the first radar detection device in the embodiment shown in FIG. 17A, such as S1702, and/or other processes used to support the technology described herein.
- the processing unit 2501 is configured to determine a first time domain range, where the first time domain range is a time domain range of L time domain ranges, and the L is a positive integer greater than 1;
- the transceiver unit 2502 is configured to send a first radar signal within the first time domain range; wherein any one of the L time domain ranges and at least one of the other L-1 time domain ranges The time domain ranges partially overlap, and the absolute value of the difference between the time domain start positions of any two time domain ranges in the L time domain ranges is greater than or equal to a first threshold and less than or equal to a second threshold; the first The threshold is determined based on at least one echo delay and at least one propagation delay, the at least one echo delay including the first echo delay corresponding to the maximum detection distance of the first radar detection device 25, and the at least one echo delay The propagation delay includes the first propagation delay corresponding to the first radar signal.
- the at least one echo delay includes a second echo delay, and the second echo delay is the echo delay corresponding to the maximum detection distance of the second radar detection device, And/or, the at least one propagation delay includes a second propagation delay, and the second propagation delay is the propagation delay corresponding to the third radar signal corresponding to the third radar detection device; wherein, the second propagation delay The wave delay is not equal to the first echo delay, and the second propagation delay is not equal to the first propagation delay.
- the first threshold value is a maximum value among a plurality of first sub-thresholds, and the plurality of first sub-threshold values are based on the at least one echo delay and the at least one propagation The delay is determined.
- the first threshold satisfies the following formula:
- Is the echo delay corresponding to the maximum detection distance of the fourth radar detection device Is the echo delay corresponding to the maximum detection distance of the fifth radar detection device
- Is the propagation delay corresponding to the fourth radar signal Is the propagation delay corresponding to the fifth radar signal
- a 1 is the frequency change of the fourth radar signal per unit time
- a 2 is the frequency change of the fifth radar signal per unit time
- T c is The frequency sweep time of the fourth radar detection device
- the fourth radar signal corresponds to the fourth radar detection device
- the fifth radar signal corresponds to the fifth radar detection device
- ⁇ is a time margin
- the synchronization error is the synchronization error between the fourth radar detection device and the fifth radar detection device.
- the propagation delay corresponding to the fourth radar signal is the maximum propagation delay corresponding to the fourth radar signal
- the propagation delay corresponding to the fifth radar signal is the fifth The maximum propagation delay corresponding to the radar signal.
- the second threshold is determined according to the at least one echo delay and the at least one propagation delay.
- the second threshold value is a minimum value among a plurality of second sub-thresholds, and the plurality of second sub-threshold values are based on the at least one echo delay and the at least one propagation The delay is determined.
- the second threshold satisfies the following formula:
- Is the echo delay corresponding to the maximum detection distance of the sixth radar detection device Is the echo delay corresponding to the maximum detection distance of the seventh radar detection device
- Is the propagation delay corresponding to the sixth radar signal Is the propagation delay corresponding to the seventh radar signal
- a 1 is the frequency change of the sixth radar signal per unit time
- a 2 is the frequency change of the seventh radar signal per unit time
- T c is The frequency sweep time of the sixth radar detection device
- the sixth radar signal corresponds to the sixth radar detection device
- the seventh radar signal corresponds to the seventh radar detection device
- ⁇ is a time margin
- the synchronization error is the synchronization error between the sixth radar detection device and the seventh radar detection device.
- the propagation delay corresponding to the fourth radar signal is the maximum propagation delay corresponding to the fourth radar signal
- the propagation delay corresponding to the fifth radar signal is the fifth The maximum propagation delay corresponding to the radar signal.
- the first threshold satisfies the following formula:
- Is the echo delay corresponding to the maximum detection distance of the fourth radar detection device Is the echo delay corresponding to the maximum detection distance of the fifth radar detection device
- Is the propagation delay corresponding to the fourth radar signal Is the propagation delay corresponding to the fifth radar signal
- a 1 is the frequency change of the fourth radar signal per unit time
- a 2 is the frequency change of the fifth radar signal per unit time
- T c is The frequency sweep time of the fourth radar detection device
- the fourth radar signal corresponds to the fourth radar detection device
- the fifth radar signal corresponds to the fifth radar detection device
- ⁇ is a time margin
- the synchronization error is the synchronization error between the fourth radar detection device and the fifth radar detection device.
- the second threshold is determined according to the at least one echo delay and the at least one propagation delay.
- the second threshold value is a minimum value among a plurality of second sub-thresholds, and the plurality of second sub-threshold values are based on the at least one echo delay and the at least one propagation The delay is determined.
- the second threshold satisfies the following formula:
- Is the echo delay corresponding to the maximum detection distance of the sixth radar detection device Is the echo delay corresponding to the maximum detection range of the seventh radar detection device
- Is the propagation delay corresponding to the sixth radar signal Is the propagation delay corresponding to the seventh radar signal
- a 1 is the frequency change of the sixth radar signal per unit time
- a 2 is the frequency change of the seventh radar signal per unit time
- T c is the sixth radar signal.
- the propagation time delay corresponding to the fourth radar signal is the time delay for the fourth radar signal to reach the fifth radar detection device from the fourth radar detection device
- the first The propagation time delay corresponding to the fifth radar signal is the time delay of the fifth radar signal from the fifth radar detection device to the fourth radar detection device.
- the first radar detection device 25 may further include a storage unit 2503 for storing program instructions and/or data for the processing unit 2501 to read.
- This optional design can be implemented independently or integrated with any of the above optional designs.
- FIG. 26 is a schematic diagram of another possible structure of the first radar detection device provided by an embodiment of this application.
- the first radar detection device 26 may include a processor 2601, a transmitter 2602, and a receiver 2603. The functions thereof can respectively correspond to the specific functions of the processing unit 2501 and the transceiver unit 2502 shown in FIG. 25, and will not be repeated here.
- the first radar detection device 26 may further include a memory 2604 for storing program instructions and/or data for the processor 2601 to read.
- FIG. 1 provides a schematic structural diagram of a radar device.
- Fig. 27 provides a schematic diagram of another possible structure of the first radar detection device.
- the first radar detection device provided in FIGS. 25-27 may be part or all of the radar device in the actual communication scenario, or may be a functional module integrated in the radar device or located outside the radar device, such as a chip system.
- the realization of the corresponding function shall prevail, and the structure and composition of the first radar detection device are not specifically limited.
- the first radar detection device 27 includes a transmitting antenna 2701, a receiving antenna 2702, and a processor 2703. Further, the first radar detection device further includes a mixer 2704 and/or an oscillator 2705. Further, the first radar detection device 27 may also include a low-pass filter and/or a directional coupler, etc. Among them, the transmitting antenna 2701 and the receiving antenna 2702 are used to support the radio communication of the detection device, the transmitting antenna 2701 supports the transmission of radar signals, and the receiving antenna 2702 supports the reception of radar signals and/or the reception of reflected signals to finally realize the detection function .
- the processor 2703 performs some possible determination and/or processing functions.
- the processor 2703 also controls the operation of the transmitting antenna 2701 and/or the receiving antenna 2702. Specifically, the signal to be transmitted is transmitted by the processor 2703 controlling the transmitting antenna 2701, and the signal received through the receiving antenna 2702 can be transmitted to the processor 2703 for corresponding processing.
- the components included in the first radar detection device 27 can be used to cooperate with the implementation of the method provided in the embodiment shown in FIG. 17A.
- the first radar detection device may further include a memory for storing program instructions and/or data.
- the transmitting antenna 2701 and the receiving antenna 2702 may be set independently, or may be integratedly set as a transmitting and receiving antenna to perform corresponding transmitting and receiving functions.
- FIG. 28 is a schematic structural diagram of an apparatus 28 provided by an embodiment of this application.
- the device 28 shown in FIG. 28 may be the first radar detection device itself, or may be a chip or circuit capable of completing the function of the first radar detection device.
- the chip or circuit may be provided in the first radar detection device.
- the device 28 shown in FIG. 28 may include a processor 2801 (for example, the processing unit 2501 may be implemented by the processor 2801, and the processor 2601 and the processor 2801 may be the same component, for example) and an interface circuit 2802 (for example, the transceiver unit 2502 may be implemented by the interface circuit 2802 implementation, the transmitter 2602 and the receiver 2603 and the interface circuit 2802 are, for example, the same component).
- a processor 2801 for example, the processing unit 2501 may be implemented by the processor 2801, and the processor 2601 and the processor 2801 may be the same component, for example
- an interface circuit 2802 for example, the transceiver unit 2502 may be implemented by the interface circuit 2802 implementation
- the processor 2801 can enable the device 28 to implement the steps performed by the first radar detection device in the method provided in the embodiment shown in FIG. 17A.
- the device 28 may further include a memory 2803, and the memory 2803 may be used to store instructions.
- the processor 2801 executes the instructions stored in the memory 2803 to enable the device 28 to implement the steps performed by the first radar detection device in the method provided in the embodiment shown in FIG. 17A.
- the processor 2801, the interface circuit 2802, and the memory 2803 can communicate with each other through an internal connection path to transfer control and/or data signals.
- the memory 2803 is used to store computer programs.
- the processor 2801 can call and run the computer programs from the memory 2803 to control the interface circuit 2802 to receive signals or send signals to complete the first radar detection in the method provided by the embodiment shown in FIG. 17A The steps performed by the device.
- the memory 2803 may be integrated in the processor 2801, or may be provided separately from the processor 2801.
- the interface circuit 2802 may include a receiver and a transmitter.
- the receiver and the transmitter may be the same component or different components.
- the component can be called a transceiver.
- the interface circuit 2802 may include an input interface and an output interface, and the input interface and the output interface may be the same interface, or may be different interfaces respectively.
- the device 28 may not include the memory 2803, and the processor 2801 may read instructions (programs or codes) in the memory outside the chip or circuit to implement the implementation shown in FIG. 17A The steps performed by the first radar detection device in the method provided in the example.
- the device 28 may include a resistor, a capacitor, or other corresponding functional components, and the processor 2801 or the interface circuit 2802 may be implemented by corresponding functional components.
- the function of the interface circuit 2802 may be implemented by a transceiver circuit or a dedicated chip for transceiver.
- the processor 2801 may be implemented by a dedicated processing chip, a processing circuit, a processor, or a general-purpose chip.
- a general-purpose computer may be considered to implement the first radar detection device provided in the embodiment of the present application. That is, the program codes for realizing the functions of the processor 2801 and the interface circuit 2802 are stored in the memory 2803, and the processor 2801 implements the functions of the processor 2801 and the interface circuit 2802 by executing the program codes stored in the memory 2803.
- the functions and actions of the modules or units in the device 28 listed above are only exemplary, and the functional units in the device 28 can be used to perform the actions or actions performed by the first radar detection device in the embodiment shown in FIG. 17A. Processing process. In order to avoid redundant description, detailed description is omitted here.
- the second radar detection device, the third radar detection device, the fourth radar detection device, or the fifth radar detection device may have the same structure as the first radar detection device, that is, the same applies to FIGS. 25-28 Schematic diagram of the structure described in.
- the radar detection device when implemented by software, it can be implemented in the form of a computer program product in whole or in part.
- the computer program product includes one or more computer instructions.
- the computer may be a general-purpose computer, a special-purpose computer, a computer network, or other programmable devices.
- the computer instructions may be stored in a computer-readable storage medium or transmitted from one computer-readable storage medium to another computer-readable storage medium.
- the computer instructions may be transmitted from a website, computer, server, or data center.
- the computer-readable storage medium may be any available medium that can be accessed by a computer or a data storage device such as a server or a data center integrated with one or more available media.
- the usable medium may be a magnetic medium (for example, a floppy disk, a hard disk, and a magnetic tape), an optical medium (for example, a DVD), or a semiconductor medium (for example, a solid state disk (SSD)).
- the processor included in the detection device used to execute the detection method provided in the embodiment of the present application may be a central processing unit (CPU), a general-purpose processor, or a digital signal processor (digital signal processor).
- processor DSP
- ASIC application-specific integrated circuit
- FPGA field programmable gate array
- the processor may also be a combination for realizing computing functions, for example, including a combination of one or more microprocessors, a combination of a DSP and a microprocessor, and so on.
- the steps of the method or algorithm described in the embodiments of the present application may be implemented in a hardware manner, or may be implemented in a manner in which a processor executes software instructions.
- Software instructions can be composed of corresponding software modules, which can be stored in random access memory (RAM), flash memory, read-only memory (ROM) memory, erasable programmable read-only Memory (erasable programmable read-only memory, EPROM), electrically erasable programmable read-only memory (EEPROM), registers, hard disks, mobile hard drives, compact discs (read-only memory) , CD-ROM) or any other form of storage medium known in the art.
- An exemplary storage medium is coupled to the processor, so that the processor can read information from the storage medium and can write information to the storage medium.
- the storage medium may also be an integral part of the processor.
- the processor and the storage medium may be located in the ASIC.
- the ASIC may be located in the detection device.
- the processor and the storage medium may also exist as separate components in the detection device.
- FIGS. 25-28 only show the simplified design of the radar detection device.
- a radar detection device can include any number of transmitters, receivers, processors, controllers, memories, and other possible components.
- An embodiment of the present application also provides a communication system, which includes at least one radar detection device corresponding to at least one echo delay and at least one propagation delay mentioned in the foregoing embodiment of the present application.
- An embodiment of the present application also provides a communication system, which includes at least one radar detection device and/or at least one central processing unit/central controller that executes the foregoing embodiments of the present application.
- the central processing unit/central controller is used to control the driving of the vehicle and/or the processing of other radar detection devices according to the output of the at least one radar detection device.
- the central processing unit/central controller may be located in the vehicle, or other possible locations, subject to the realization of the control.
- the disclosed device and method may be implemented in other ways.
- the device embodiments described above are merely illustrative.
- the division of the modules or units is only a logical function division.
- there may be other division methods for example, multiple units or components may be It can be combined or integrated into another device, or some features can be omitted or not implemented.
- the displayed or discussed mutual coupling or direct coupling or communication connection may be indirect coupling or communication connection through some interfaces, devices or units, and may be in electrical, mechanical or other forms.
- the units described as separate parts may or may not be physically separate.
- the parts displayed as units may be one physical unit or multiple physical units, that is, they may be located in one place, or they may be distributed to multiple different places. . Some or all of the units may be selected according to actual needs to achieve the objectives of the solutions of the embodiments.
- each unit in each embodiment of the present application may be integrated into one processing unit, or each unit may exist alone physically, or two or more units may be integrated into one unit.
- the above-mentioned integrated unit can be implemented in the form of hardware or software functional unit.
- the integrated unit is implemented in the form of a software functional unit and sold or used as an independent product, it can be stored in a readable storage medium.
- the technical solutions of the embodiments of the present application are essentially or the part that contributes to the prior art, or all or part of the technical solutions can be embodied in the form of software products, which are stored in a storage medium.
- a device which may be a single-chip microcomputer, a chip, etc.
- a processor processor
- the aforementioned storage media include: U disk, mobile hard disk, ROM, RAM, magnetic disk or optical disk and other media that can store program codes.
Landscapes
- Engineering & Computer Science (AREA)
- Radar, Positioning & Navigation (AREA)
- Remote Sensing (AREA)
- Computer Networks & Wireless Communication (AREA)
- Physics & Mathematics (AREA)
- General Physics & Mathematics (AREA)
- Electromagnetism (AREA)
- Radar Systems Or Details Thereof (AREA)
Abstract
属于传感器技术领域,涉及一种雷达信号发送方法及设备,尤其涉及协同式雷达。确定第一时域范围,第一时域范围为L个时域范围中的时域范围数;在第一时域范围内发送第一雷达信号;L个时域范围中任一个时域范围与其它L-1个时域范围中至少一个时域范围部分重叠,L个时域范围中任两个时域范围的时域起始位置的差值的绝对值大于或等于第一阈值且小于或等于第二阈值。第一阈值是根据至少一个回波时延和至少一个传播时延确定的。L个时域范围可理解为时域栅格,为雷达提供可用时域资源。可应用于自动驾驶、辅助驾驶、智能驾驶、智能网联车、智能汽车等领域,例如用于目标探测和跟踪,能降低探测装置,尤其是协同式雷达之间的干扰。
Description
相关申请的交叉引用
本申请要求在2019年05月31日提交国家知识产权局、申请号为201910473501.4、申请名称为“一种雷达信号发送方法及设备”的中国专利申请的优先权,其全部内容通过引用结合在本申请中。
本申请涉及通信技术领域,尤其涉及一种雷达信号发送方法及设备。
随着社会的发展,现代生活中越来越多的机器向自动化、智能化发展,移动出行用的汽车也不例外,智能汽车正在逐步进入人们的日常生活中。近些年,高级驾驶辅助系统(advanced driving assistant system,ADAS)在智能汽车中发挥着十分重要的作用,该系统利用安装在车上的各式各样的传感器,在汽车行驶过程中感应周围的环境、收集数据,进行静止、移动物体的辨识、侦测与追踪,并结合导航仪地图数据,进行系统的运算与分析,从而预先让驾驶者察觉到可能发生的危险,有效增加了汽车驾驶的舒适性和安全性。
在无人驾驶架构中,传感层包括车载摄像头等视觉系传感器和车载毫米波雷达、车载激光雷达和车载超声波雷达等雷达系传感器。毫米波雷达由于成本较低、技术比较成熟,率先成为无人驾驶系统主力传感器。目前ADAS已开发出十多项功能,其中,自适应巡航控制(adaptive cruise control,ACC)、自动紧急制动(autonomous emergency braking,AEB)、变道辅助(lance change assist,LCA)、或盲点监测(blind spot monitoring,BSD)等都离不开车载毫米波雷达。毫米波是指波长介于1~10mm之间的电磁波,所对应的频率范围为30~300GHz。在这个频段,毫米波相关的特性非常适合应用于车载领域。例如,带宽大,频域资源丰富,天线副瓣低,有利于实现成像或准成像;波长短,雷达设备体积和天线口径得以减小,重量减轻;波束窄,在相同天线尺寸下毫米波的波束要比微波的波束窄得多,雷达分辨率高;穿透强,相比于激光雷达和光学系统,更加具有穿透烟、灰尘和雾的能力,可全天候工作。
随着车载雷达的广泛使用,车载雷达之间的互干扰越来越严重。由于互干扰会降低车载雷达检测概率或提升其虚警概率,对车辆行驶安全或舒适性造成不可忽视的影响。在这种前提下,如何减小车载雷达之间的干扰是亟需解决的一个技术问题。
发明内容
本申请实施例提供一种雷达信号发送方法及设备,用于尽量减小或避免雷达之间的干扰。
第一方面,提供一种雷达信号发送方法,该方法包括:确定第一时域范围,所述第一时域范围为L个时域范围中的时域范围,所述L为大于1的正整数;在所述第一时域范围内发送第一雷达信号;其中,所述L个时域范围中的任一个时域范围与其它L-1个时域范 围中的至少一个时域范围部分重叠,所述L个时域范围中任两个时域范围的时域起始位置的差值的绝对值大于或等于第一阈值且小于或等于第二阈值;所述第一阈值是根据至少一个回波时延和至少一个传播时延确定的,所述至少一个回波时延包含所述第一雷达探测装置的最大探测距离对应的第一回波时延,所述至少一个传播时延包括所述第一雷达信号对应的第一传播时延。
该方法可由探测装置执行,探测装置例如为雷达探测装置。其中,执行该方法的雷达探测装置可称为第一雷达探测装置。
在本申请实施例中,L个时域范围中的任意两个时域范围的时域起始位置的差值的绝对值可以大于或等于第一阈值以及小于或等于第二阈值,第一阈值是根据至少一个回波时延和至少一个传播时延确定的,例如任意两个时域范围的时域起始位置的差值的绝对值都需要大于或等于至少一个回波时延和至少一个传播时延中的最大值,而在一个时域范围只允许一个雷达探测装置进行发送,这样,一个雷达探测装置发送的雷达信号就不会落到其他雷达探测装置的有效接收区域内,不会被其他雷达探测装置当做接收信号处理,而其他雷达探测装置所发送的雷达信号也不会落到第一雷达探测装置的有效接收区域内,不会被第一雷达探测装置当做接收信号处理。通过这种方式,可以减小雷达探测装置之间的干扰。
结合第一方面,在第一方面的一种可能的实施方式中,
所述至少一个回波时延包含第二回波时延,所述第二回波时延为第二雷达探测装置的最大探测距离对应的回波时延,和/或,所述至少一个传播时延包含第二传播时延,所述第二传播时延为第三雷达探测装置对应的第三雷达信号对应的传播时延;
其中,所述第二回波时延不等于所述第一回波时延,所述第二传播时延不等于所述第一传播时延。
至少一个回波时延除了包括第一回波时延之外,还可以包括其他的雷达探测装置的回波时延。例如,还包括第二雷达探测装置对应的第二回波时延。第二回波时延可以等于第一回波时延,也可以不等于第一回波时延。如果第二回波时延不等于第一回波时延,就表明第二雷达探测装置和第一雷达探测装置的类别不同,在这种情况下,第二雷达探测装置所发送的雷达信号的传播时延可以等于第一传播时延,也可以不等于第一传播时延,不再做限制。至少一个传播时延除了包括第一传播时延之外,还可以包括其他的雷达探测装置对应的雷达信号的传播时延。例如,还包括第三雷达探测装置对应的第二传播时延。第二传播时延可以等于第一传播时延,也可以不等于第一传播时延。如果第二传播时延不等于第一传播时延,就表明第三雷达探测装置和第一雷达探测装置的类别不同,在这种情况下,第三雷达探测装置所发送的第三雷达信号的回波时延可以等于第一回波时延,也可以不等于第一回波时延,不再做限制。第二雷达探测装置和第三雷达探测装置可以是同一个雷达探测装置,或者也可以是不同的雷达探测装置。
结合第一方面,在第一方面的一种可能的实施方式中,所述第一阈值为多个第一子阈值中的最大值,所述多个第一子阈值为根据所述至少一个回波时延和所述至少一个传播时延确定的。
例如,根据至少一个回波时延和至少一个回波时延可以确定多个第一子阈值,多个第一子阈值中的最大值就可以作为第一阈值。相当于,如果参与计算的雷达探测装置的数量大于2,则可以根据每两个雷达探测装置计算得到一个第一子阈值,再将得到的第一子阈值中的最大值作为第一阈值,使得所确定的第一阈值能够符合多个雷达探测装置的情况, 使得多个雷达探测装置之间均实现无干扰。
结合第一方面,在第一方面的一种可能的实施方式中,所述第一阈值满足如下公式:


其中,
 为第四雷达探测装置的最大探测距离所对应的回波时延,
 为第五雷达探测装置的最大探测距离所对应的回波时延,
 为第四雷达信号对应的传播时延,
 为第五雷达信号对应的传播时延,a
1为所述第四雷达信号在单位时间内的频率变化量,a
2为所述第五雷达信号在单位时间内的频率变化量,T
c为所述第四雷达探测装置的扫频时间,所述第四雷达信号对应于所述第四雷达探测装置,所述第五雷达信号对应于所述第五雷达探测装置,Δ为时间余量,或为同步误差,或为时间余量与同步误差之和,所述同步误差为所述第四雷达探测装置和所述第五雷达探测装置之间的同步误差。
结合第一方面,在第一方面的一种可能的实施方式中,所述第四雷达信号对应的传播时延为所述第四雷达信号对应的最大传播时延,所述第五雷达信号对应的传播时延为所述第五雷达信号对应的最大传播时延。
给出了计算第一阈值的一种方式。这种情况例如可以适用于第四雷达探测装置和第五雷达探测装置的位置不固定的情况,例如第四雷达探测装置和第五雷达探测装置都是车载雷达探测装置。那么,第四雷达信号对应的传播时延,可以是指第四雷达信号对应的最大传播时延,同理,第五雷达信号对应的传播时延,可以是指第五雷达信号对应的最大传播时延。第四雷达探测装置或第五雷达探测装置可以是第一雷达探测装置,或者第四雷达探测装置和第五雷达探测装置都不是第一雷达探测装置,具体的不做限制。
结合第一方面,在第一方面的一种可能的实施方式中,所述第二阈值是根据所述至少一个回波时延和所述至少一个传播时延确定的。
根据至少一个回波时延和至少一个传播时延除了可以确定第一阈值之外,也可以确定第二阈值。或者,第二阈值也可以采用其他的确定方式,具体的不做限制。
结合第一方面,在第一方面的一种可能的实施方式中,所述第二阈值为多个第二子阈值中的最小值,所述多个第二子阈值为根据所述至少一个回波时延和所述至少一个传播时延确定的。
例如,根据至少一个回波时延和至少一个回波时延可以确定多个第二子阈值,多个第二子阈值中的最小值就可以作为第二阈值。相当于,如果参与计算的雷达探测装置的数量大于2,则可以根据每两个雷达探测装置计算得到一个第二子阈值,再将得到的第二子阈值中的最小值作为第二阈值,使得所确定的第二阈值能够符合多个雷达探测装置的情况,使得多个雷达探测装置之间均实现无干扰。
结合第一方面,在第一方面的一种可能的实施方式中,所述第二阈值满足如下公式:


其中,
 为第六雷达探测装置的最大探测距离所对应的回波时延,
 为第七雷达探测装置的最大探测距离所对应的回波时延,
 为第六雷达信号对应的传播时延,
 为第七雷达信号对应的传播时延,a
1为所述第六雷达信号在单位时间内的频率变化量,a
2为所述第七雷达信号在单位时间内的频率变化量,T
c为所述第六雷达探测装置的扫频时间,所述第六雷达信号对应于所述第六雷达探测装置,所述第七雷达信号对应于所述第七雷达探测装置,Δ为时间余量,或为同步误差,或为时间余量与同步误差之和,所述同步误差为所述第六雷达探测装置和所述第七雷达探测装置之间的同步误差。
给出了计算第二阈值的一种方式。这种情况例如可以适用于第六雷达探测装置和第七雷达探测装置的位置不固定的情况,例如第六雷达探测装置和第七雷达探测装置都是车载雷达探测装置。那么,第六雷达信号对应的传播时延,可以是指第六雷达信号对应的最大传播时延,同理,第七雷达信号对应的传播时延,可以是指第七雷达信号对应的最大传播时延。
第六探测装置和第四探测装置可以是同一个探测装置,或者是不同的探测装置,第七探测装置和第五探测装置可以是同一个探测装置,或者是不同的探测装置。
结合第一方面,在第一方面的一种可能的实施方式中,所述第六雷达信号对应的传播时延为所述第六雷达信号对应的最大传播时延,所述第七雷达信号对应的传播时延为所述第七雷达信号对应的最大传播时延。
雷达信号的最大传播时延,可以是指相应的雷达探测装置的干扰最大容忍距离对应的传播时延。
结合第一方面,在第一方面的一种可能的实施方式中,所述第一阈值满足如下公式:


其中,
 为第四雷达探测装置的最大探测距离所对应的回波时延,
 为第五雷达探测装置的最大探测距离所对应的回波时延,
 为第四雷达信号对应的传播时延,
 为第五雷达信号对应的传播时延,a
1为所述第四雷达信号在单位时间内的频率变化量,a
2为所述第五雷达信号在单位时间内的频率变化量,T
c为所述第四雷达探测装置的扫频时间,所述第四雷达信号对应于所述第四雷达探测装置,所述第五雷达信号对应于所述第五雷达探测装置,Δ为时间余量,或为同步误差,或为时间余量与同步误差之和,所述同步误差为所述第四雷达探测装置和所述第五雷达探测装置之间的同步误差。
给出了计算第一阈值的另一种方式。这种情况例如可以适用于第四雷达探测装置和第五雷达探测装置的位置固定的情况,例如第四雷达探测装置和第五雷达探测装置设置在RSU上,或者设置在基站上,或者第四雷达探测装置设置在RSU上,第五雷达探测装置设置在基站上,等等。那么,第四雷达信号对应的传播时延,可以是指第四雷达信号从第四雷达探测装置到达第五雷达探测装置的时延,同理,第五雷达信号对应的传播时延,可 以是指第五雷达信号从第五雷达探测装置到达第四雷达探测装置的时延。
结合第一方面,在第一方面的一种可能的实施方式中,所述第二阈值是根据所述至少一个回波时延和所述至少一个传播时延确定的。
结合第一方面,在第一方面的一种可能的实施方式中,所述第二阈值为多个第二子阈值中的最小值,所述多个第二子阈值为根据所述至少一个回波时延和所述至少一个传播时延确定的。
结合第一方面,在第一方面的一种可能的实施方式中,所述第二阈值满足如下公式:


其中,
 为第六雷达探测装置的最大探测距离所对应的回波时延,
 为第七雷达探测装置的最大探测距离所对应的回波时延,
 为第六雷达信号对应的传播时延,
 为第七雷达信号对应的传播时延,a
1为第六雷达信号在单位时间内的频率变化量,a
2为第七雷达信号在单位时间内的频率变化量,T
c为所述第六雷达探测装置的扫频时间,所述第六雷达信号对应于所述第六雷达探测装置,所述第七雷达信号对应于所述第七雷达探测装置,Δ为时间余量,或为同步误差,或为时间余量与同步误差之和,所述同步误差为所述第六雷达探测装置和所述第七雷达探测装置之间的同步误差。
给出了计算第二阈值的另一种方式。这种情况例如可以适用于第六雷达探测装置和第七雷达探测装置的位置固定的情况,例如第六雷达探测装置和第七雷达探测装置设置在RSU上,或者设置在基站上,或者第六雷达探测装置设置在RSU上,第七雷达探测装置设置在基站上,等等。那么,第六雷达信号对应的传播时延,可以是指第六雷达信号从第六雷达探测装置到达第七雷达探测装置的时延,同理,第七雷达信号对应的传播时延,可以是指第七雷达信号从第七雷达探测装置到达第六雷达探测装置的时延。
结合第一方面,在第一方面的一种可能的实施方式中,所述第六雷达信号对应的传播时延为所述第六雷达信号从所述第六雷达探测装置到达所述第七雷达探测装置的时延,所述第七雷达信号对应的传播时延为所述第七雷达信号从所述第七雷达探测装置到达所述第六雷达探测装置的时延。
第二方面,提供第一种探测装置,例如该探测装置为如前所述的第一雷达探测装置。所述探测装置用于执行上述第一方面或第一方面的任一可能的实现方式中的方法。具体地,所述探测装置可以包括用于执行第一方面或第一方面的任一可能的实现方式中的方法的模块,例如包括处理单元和收发单元。其中,
所述处理单元,用于确定第一时域范围,所述第一时域范围为L个时域范围中的时域范围,所述L为大于1的正整数;
所述收发单元,用于在所述第一时域范围内发送第一雷达信号;
其中,所述L个时域范围中的任一个时域范围与其它L-1个时域范围中的至少一个时域范围部分重叠,所述L个时域范围中任两个时域范围的时域起始位置的差值的绝对值大于或等于第一阈值且小于或等于第二阈值;所述第一阈值是根据至少一个回波时延和至少一个传播时延确定的,所述至少一个回波时延包含所述第一雷达探测装置的最大探测距离 对应的第一回波时延,所述至少一个传播时延包括所述第一雷达信号对应的第一传播时延。
结合第二方面,在第二方面的一种可能的实施方式中,
所述至少一个回波时延包含第二回波时延,所述第二回波时延为第二雷达探测装置的最大探测距离对应的回波时延,和/或,
所述至少一个传播时延包含第二传播时延,所述第二传播时延为第三雷达探测装置对应的第三雷达信号对应的传播时延;
其中,所述第二回波时延不等于所述第一回波时延,所述第二传播时延不等于所述第一传播时延。
结合第二方面,在第二方面的一种可能的实施方式中,所述第一阈值为多个第一子阈值中的最大值,所述多个第一子阈值为根据所述至少一个回波时延和所述至少一个传播时延确定的。
结合第二方面,在第二方面的一种可能的实施方式中,所述第一阈值满足如下公式:


其中,
 为第四雷达探测装置的最大探测距离所对应的回波时延,
 为第五雷达探测装置的最大探测距离所对应的回波时延,
 为第四雷达信号对应的传播时延,
 为第五雷达信号对应的传播时延,a
1为所述第四雷达信号在单位时间内的频率变化量,a
2为所述第五雷达信号在单位时间内的频率变化量,T
c为所述第四雷达探测装置的扫频时间,所述第四雷达信号对应于所述第四雷达探测装置,所述第五雷达信号对应于所述第五雷达探测装置,Δ为时间余量,或为同步误差,或为时间余量与同步误差之和,所述同步误差为所述第四雷达探测装置和所述第五雷达探测装置之间的同步误差。
结合第二方面,在第二方面的一种可能的实施方式中,所述第四雷达信号对应的传播时延为所述第四雷达信号对应的最大传播时延,所述第五雷达信号对应的传播时延为所述第五雷达信号对应的最大传播时延。
结合第二方面,在第二方面的一种可能的实施方式中,所述第二阈值是根据所述至少一个回波时延和所述至少一个传播时延确定的。
结合第二方面,在第二方面的一种可能的实施方式中,所述第二阈值为多个第二子阈值中的最小值,所述多个第二子阈值为根据所述至少一个回波时延和所述至少一个传播时延确定的。
结合第二方面,在第二方面的一种可能的实施方式中,所述第二阈值满足如下公式:


其中,
 为第六雷达探测装置的最大探测距离所对应的回波时延,
 为第七雷达探测装置的最大探测距离所对应的回波时延,
 为第六雷达信号对应的传播时延,
 为第七雷达信号对应的传播时延,a
1为所述第六雷达信号在单位时间内的频率变化量,a
2 为所述第七雷达信号在单位时间内的频率变化量,T
c为所述第六雷达探测装置的扫频时间,所述第六雷达信号对应于所述第六雷达探测装置,所述第七雷达信号对应于所述第七雷达探测装置,Δ为时间余量,或为同步误差,或为时间余量与同步误差之和,所述同步误差为所述第六雷达探测装置和所述第七雷达探测装置之间的同步误差。
结合第二方面,在第二方面的一种可能的实施方式中,所述第六雷达信号对应的传播时延为所述第六雷达信号对应的最大传播时延,所述第七雷达信号对应的传播时延为所述第七雷达信号对应的最大传播时延。
结合第二方面,在第二方面的一种可能的实施方式中,所述第一阈值满足如下公式:


其中,
 为第四雷达探测装置的最大探测距离所对应的回波时延,
 为第五雷达探测装置的最大探测距离所对应的回波时延,
 为第四雷达信号对应的传播时延,
 为第五雷达信号对应的传播时延,a
1为所述第四雷达信号在单位时间内的频率变化量,a
2为所述第五雷达信号在单位时间内的频率变化量,T
c为所述第四雷达探测装置的扫频时间,所述第四雷达信号对应于所述第四雷达探测装置,所述第五雷达信号对应于所述第五雷达探测装置,Δ为时间余量,或为同步误差,或为时间余量与同步误差之和,所述同步误差为所述第四雷达探测装置和所述第五雷达探测装置之间的同步误差。
结合第二方面,在第二方面的一种可能的实施方式中,所述第二阈值是根据所述至少一个回波时延和所述至少一个传播时延确定的。
结合第二方面,在第二方面的一种可能的实施方式中,所述第二阈值为多个第二子阈值中的最小值,所述多个第二子阈值为根据所述至少一个回波时延和所述至少一个传播时延确定的。
结合第二方面,在第二方面的一种可能的实施方式中,所述第二阈值满足如下公式:


其中,
 为第六雷达探测装置的最大探测距离所对应的回波时延,
 为第七雷达探测装置的最大探测距离所对应的回波时延,
 为第六雷达信号对应的传播时延,
 为第七雷达信号对应的传播时延,a
1为第六雷达信号在单位时间内的频率变化量,a
2为第七雷达信号在单位时间内的频率变化量,T
c为所述第六雷达探测装置的扫频时间,所述第六雷达信号对应于所述第六雷达探测装置,所述第七雷达信号对应于所述第七雷达探测装置,Δ为时间余量,或为同步误差,或为时间余量与同步误差之和,所述同步误差为所述第六雷达探测装置和所述第七雷达探测装置之间的同步误差。
结合第二方面,在第二方面的一种可能的实施方式中,所述第四雷达信号对应的传播时延为所述第四雷达信号从所述第四雷达探测装置到达所述第五雷达探测装置的时延,所述第五雷达信号对应的传播时延为所述第五雷达信号从所述第五雷达探测装置到达所述第四雷达探测装置的时延。
关于第二方面或第二方面的各种可能的实施方式的技术效果,可以参考对于第一方面或第一方面的相应的实施方式的技术效果的介绍。
第三方面,提供第二种探测装置,该探测装置例如为如前所述的第一雷达探测装置。该探测装置包括处理器、发射器和接收器,处理器、发射器和接收器相互耦合,用于实现上述第一方面或第一方面的各种可能的设计所描述的方法。示例性地,所述探测装置为设置在探测设备中的芯片。示例性的,所述探测设备为雷达。其中,发射器和接收器例如通过通信设备中的天线、馈线和编解码器等实现,或者,如果所述探测装置为设置在探测设备中的芯片,那么发射器和接收器例如为芯片中的通信接口,该通信接口与探测设备中的射频收发组件连接,以通过射频收发组件实现信息的收发。其中,
所述处理器,用于确定第一时域范围,所述第一时域范围为L个时域范围中的时域范围,所述L为大于1的正整数;
所述发射器,用于在所述第一时域范围内发送第一雷达信号;
其中,所述L个时域范围中的任一个时域范围与其它L-1个时域范围中的至少一个时域范围部分重叠,所述L个时域范围中任两个时域范围的时域起始位置的差值的绝对值大于或等于第一阈值且小于或等于第二阈值;所述第一阈值是根据至少一个回波时延和至少一个传播时延确定的,所述至少一个回波时延包含所述第一雷达探测装置的最大探测距离对应的第一回波时延,所述至少一个传播时延包括所述第一雷达信号对应的第一传播时延。
结合第三方面,在第三方面的一种可能的实施方式中,
所述至少一个回波时延包含第二回波时延,所述第二回波时延为第二雷达探测装置的最大探测距离对应的回波时延,和/或,
所述至少一个传播时延包含第二传播时延,所述第二传播时延为第三雷达探测装置对应的第三雷达信号对应的传播时延;
其中,所述第二回波时延不等于所述第一回波时延,所述第二传播时延不等于所述第一传播时延。
结合第三方面,在第三方面的一种可能的实施方式中,所述第一阈值为多个第一子阈值中的最大值,所述多个第一子阈值为根据所述至少一个回波时延和所述至少一个传播时延确定的。
结合第三方面,在第三方面的一种可能的实施方式中,所述第一阈值满足如下公式:


其中,
 为第四雷达探测装置的最大探测距离所对应的回波时延,
 为第五雷达探测装置的最大探测距离所对应的回波时延,
 为第四雷达信号对应的传播时延,
 为第五雷达信号对应的传播时延,a
1为所述第四雷达信号在单位时间内的频率变化量,a
2为所述第五雷达信号在单位时间内的频率变化量,T
c为所述第四雷达探测装置的扫频时 间,所述第四雷达信号对应于所述第四雷达探测装置,所述第五雷达信号对应于所述第五雷达探测装置,Δ为时间余量,或为同步误差,或为时间余量与同步误差之和,所述同步误差为所述第四雷达探测装置和所述第五雷达探测装置之间的同步误差。
结合第三方面,在第三方面的一种可能的实施方式中,所述第四雷达信号对应的传播时延为所述第四雷达信号对应的最大传播时延,所述第五雷达信号对应的传播时延为所述第五雷达信号对应的最大传播时延。
结合第三方面,在第三方面的一种可能的实施方式中,所述第二阈值是根据所述至少一个回波时延和所述至少一个传播时延确定的。
结合第三方面,在第三方面的一种可能的实施方式中,所述第二阈值为多个第二子阈值中的最小值,所述多个第二子阈值为根据所述至少一个回波时延和所述至少一个传播时延确定的。
结合第三方面,在第三方面的一种可能的实施方式中,所述第二阈值满足如下公式:


其中,
 为第六雷达探测装置的最大探测距离所对应的回波时延,
 为第七雷达探测装置的最大探测距离所对应的回波时延,
 为第六雷达信号对应的传播时延,
 为第七雷达信号对应的传播时延,a
1为所述第六雷达信号在单位时间内的频率变化量,a
2为所述第七雷达信号在单位时间内的频率变化量,T
c为所述第六雷达探测装置的扫频时间,所述第六雷达信号对应于所述第六雷达探测装置,所述第七雷达信号对应于所述第七雷达探测装置,Δ为时间余量,或为同步误差,或为时间余量与同步误差之和,所述同步误差为所述第六雷达探测装置和所述第七雷达探测装置之间的同步误差。
结合第三方面,在第三方面的一种可能的实施方式中,所述第四雷达信号对应的传播时延为所述第四雷达信号对应的最大传播时延,所述第五雷达信号对应的传播时延为所述第五雷达信号对应的最大传播时延。
结合第三方面,在第三方面的一种可能的实施方式中,所述第一阈值满足如下公式:


其中,
 为第四雷达探测装置的最大探测距离所对应的回波时延,
 为第五雷达探测装置的最大探测距离所对应的回波时延,
 为第四雷达信号对应的传播时延,
 为第五雷达信号对应的传播时延,a
1为所述第四雷达信号在单位时间内的频率变化量,a
2为所述第五雷达信号在单位时间内的频率变化量,T
c为所述第四雷达探测装置的扫频时间,所述第四雷达信号对应于所述第四雷达探测装置,所述第五雷达信号对应于所述第五雷达探测装置,Δ为时间余量,或为同步误差,或为时间余量与同步误差之和,所述同步 误差为所述第四雷达探测装置和所述第五雷达探测装置之间的同步误差。
结合第三方面,在第三方面的一种可能的实施方式中,所述第二阈值是根据所述至少一个回波时延和所述至少一个传播时延确定的。
结合第三方面,在第三方面的一种可能的实施方式中,所述第二阈值为多个第二子阈值中的最小值,所述多个第二子阈值为根据所述至少一个回波时延和所述至少一个传播时延确定的。
结合第三方面,在第三方面的一种可能的实施方式中,所述第二阈值满足如下公式:


其中,
 为第六雷达探测装置的最大探测距离所对应的回波时延,
 为第七雷达探测装置的最大探测距离所对应的回波时延,
 为第六雷达信号对应的传播时延,
 为第七雷达信号对应的传播时延,a
1为第六雷达信号在单位时间内的频率变化量,a
2为第七雷达信号在单位时间内的频率变化量,T
c为所述第六雷达探测装置的扫频时间,所述第六雷达信号对应于所述第六雷达探测装置,所述第七雷达信号对应于所述第七雷达探测装置,Δ为时间余量,或为同步误差,或为时间余量与同步误差之和,所述同步误差为所述第六雷达探测装置和所述第七雷达探测装置之间的同步误差。
结合第三方面,在第三方面的一种可能的实施方式中,所述第四雷达信号对应的传播时延为所述第四雷达信号从所述第四雷达探测装置到达所述第五雷达探测装置的时延,所述第五雷达信号对应的传播时延为所述第五雷达信号从所述第五雷达探测装置到达所述第四雷达探测装置的时延。
关于第三方面或第三方面的各种可能的实施方式的技术效果,可以参考对于第一方面或第一方面的相应的实施方式的技术效果的介绍。
第四方面,提供第三种探测装置。该探测装置可以为上述方法设计中的第一雷达探测装置。示例性地,所述探测装置为设置在探测设备中的芯片。示例性地,所述探测设备为雷达。该探测装置包括:存储器,用于存储计算机可执行程序代码;以及处理器,处理器与存储器耦合。其中存储器所存储的程序代码包括指令,当处理器执行所述指令时,使第三种探测装置执行上述第一方面或第一方面的任意一种可能的实施方式中的方法。
其中,第三种探测装置还可以包括通信接口,该通信接口可以是探测设备中的收发器,例如通过所述探测装置中的天线、馈线和编解码器等实现,或者,如果第五种探测装置为设置在探测设备中的芯片,则通信接口可以是该芯片的输入/输出接口,例如输入/输出管脚等。
第五方面,提供一种通信系统,该通信系统可以包括第二方面所述的第一种探测装置、第三方面所述的第二种探测装置或第四方面所述的第三种探测装置,以及包括其他的探测装置(例如包括第二探测装置、第三探测装置、第四探测装置或第五探测装置中的一个或多个);或者,该通信系统可以包括第二方面所述的第一种探测装置、第三方面所述的第二种探测装置或第四方面所述的第三种探测装置,以及包括目标物体;或者,该通信系统 可以包括第二方面所述的第一种探测装置、第三方面所述的第二种探测装置或第四方面所述的第三种探测装置,以及包括其他的探测装置(例如包括第二探测装置、第三探测装置、第四探测装置或第五探测装置中的一个或多个)和目标物体。
第六方面,提供一种计算机存储介质,所述计算机可读存储介质中存储有指令,当其在计算机上运行时,使得计算机执行上述第一方面或第一方面的任意一种可能的设计中所述的方法。
第七方面,提供一种包含指令的计算机程序产品,所述计算机程序产品中存储有指令,当其在计算机上运行时,使得计算机执行上述第一方面或第一方面的任意一种可能的设计中所述的方法。
在本申请实施例中,L个时域范围中的任意两个时域范围的时域起始位置的差值的绝对值可以大于或等于第一阈值以及小于或等于第二阈值,这样,一个雷达探测装置发送的雷达信号就不会落到其他雷达探测装置的有效接收区域内,不会被其他雷达探测装置当做接收信号处理,而其他雷达探测装置所发送的雷达信号也不会落到第一雷达探测装置的有效接收区域内,不会被第一雷达探测装置当做接收信号处理。通过这种方式,可以减小雷达探测装置之间的干扰。
图1提供了一种雷达装置的结构示意图;
图2为调频连续波的一种示意图;
图3为调频连续波的频率随时间线性变化的示意图;
图4提供了一种可能的发射信号、反射信号与中频信号的频率变化示意图;
图5为车载雷达之间相互干扰的一种示意图;
图6和图7提供了一种可能的虚假中频信号的示意图;
图8和图9提供了一种可能的干扰信号淹没目标信号的示意图;
图10为一种干扰平台的示意图;
图11为一种干扰平台的示意图;
图12提供了一种可能的解决方案示意图;
图13提供了一种可能的误警结果示意图;
图14提供了又一种可能的解决方案示意图;
图15提供了再一种可能的解决方案示意图;
图16为本申请实施例的一种可能的应用场景示意图;
图17A为本申请实施例提供的一种雷达信号发送方法的流程图;
图17B为本申请实施例提供的一种3个时域范围的关系示意图;
图18为本申请实施例中第四雷达探测装置的时域范围和第五雷达探测装置的时域范围的一种示意图;
图19为本申请实施例中多个雷达所在的时域范围的一种排布方式的示意图;
图20为本申请实施例中第四雷达探测装置的时域范围和第五雷达探测装置的时域范围的一种示意图;
图21为本申请实施例中在1GHz带宽内可以支持的雷达信号的示意图;
图22为本申请实施例中第四雷达探测装置的时域范围和第五雷达探测装置的时域范 围的一种示意图;
图23为本申请实施例中第四雷达探测装置的时域范围和第五雷达探测装置的时域范围的一种示意图;
图24为本申请实施例中第四雷达探测装置的时域范围和第五雷达探测装置的时域范围的一种示意图;
图25是本申请实施例提供的第一雷达探测装置的一种结构示意图;
图26是本申请实施例提供的第一雷达探测装置的又一种结构示意图;
图27是本申请实施例提供的第一雷达探测装置的再一种结构示意图;
图28是本申请实施例提供的一种装置的结构示意图。
为了使本申请实施例的目的、技术方案和优点更加清楚,下面将结合附图对本申请实施例作进一步地详细描述。
以下,对本申请实施例中的部分用语进行解释说明,以便于本领域技术人员理解。
1)雷达探测装置,例如为雷达(radar),或者也可以是其他的用于进行探测(例如,测距)的装置。
2)雷达,或称为雷达装置,也可以称为探测器、雷达探测装置或者雷达信号发送装置等。其工作原理是通过发射信号(或者称为探测信号),并接收经过目标物体反射的反射信号,来探测相应的目标物体。雷达所发射的信号可以是雷达信号,相应的,所接收的经过目标物体反射的反射信号也可以是雷达信号。
3)雷达探测装置的发射周期(或者,称为雷达探测装置的扫频周期、扫频时间或扫频时长等),是指雷达探测装置进行一个完整波形的雷达信号发射的周期。雷达探测装置一般会在一段连续的时长内进行多个扫频周期的雷达信号发送。
4)雷达探测装置的初始频率。在一个发射周期的开始,雷达探测装置的会以一个频率发射雷达信号,该频率称为雷达探测装置的初始频率。并且雷达探测装置的发射频率以该初始频率为基础在发射周期内变化。
5)雷达探测装置的扫频带宽,雷达探测装置发送的雷达信号的波形所占用的带宽。这里需要说明的是,“扫频带宽”是为了阐述方便而定义的,技术上为雷达探测装置发送的雷达信号的波形所占用的带宽。进一步的,雷达探测装置发送的雷达信号的波形所占用的频带可以称为扫频频带。
6)调频连续波(frequency modulated continuous wave,FMCW),频率随时间变化的电磁波。
7)线性调频连续波,频率随时间线性变化的电磁波。这里的线性变化一般是指在一个发射周期内线性变化。具体的,线性调频连续波的波形一般是锯齿波或者三角波,或者也可能存在其它可能的波形,例如步进频波形等。
8)雷达探测装置的最大测距距离,或称雷达探测装置的最大探测距离,是与雷达探测装置的配置有关的参数(例如,与雷达探测装置的出厂设置参数相关)。例如雷达探测装置为雷达,长距自适应巡航控制(adaptive cruise control,ACC)雷达的最大测距距离为250m,中距雷达的最大测距距离为70~150m。
9)中频(intermediate frequency,IF)信号,以雷达探测装置是雷达为例,雷达的本 振信号与雷达接收的反射信号(是雷达的发射信号经过目标物体反射后的信号)经过混频器处理后的信号,即为中频信号。具体来说,通过振荡器产生的调频连续波信号,一部分作为本振信号,一部分作为发射信号通过发射天线发射出去,而接收天线接收的发射信号的反射信号,会与本振信号混频,得到所述的“中频信号”。通过中频信号,可以得到目标物体的位置信息、速度信息或角度信息中的一个或多个。其中,位置信息可以是目标物体相对于当前的雷达的位置信息,速度信息可以是目标物体相对于当前的雷达的速度信息,角度信息可以是目标物体相对于当前的雷达的角度信息。进一步的,中频信号的频率称为中频频率。
10)雷达信号的最大传播时延,雷达信号的最大传播时延是根据当前雷达本身的属性或参数确定的,上述属性或参数具体可以包括以下中的至少一个:探测装置(作为干扰源的探测装置)雷达信号的发射功率,探测装置(当前探测装置)接收机的灵敏度。其中,详细来说,另一雷达信号经历一定的传播时延后会被当前雷达接收到,经过所述传播时延后,如果干扰信号的功率大于接收机灵敏度,则所述干扰信号会对当前雷达产生干扰,如果干扰信号的功率不大于接收机灵敏度,则所述干扰信号不会对当前雷达产生干扰,所述干扰信号会被处理为噪声。那么,经过传播时延后、干扰信号的功率若等于接收机灵敏度,则所述传播时延称为雷达信号的最大传播时延。
11)“至少一个”是指一个或者多个,“多个”是指两个或两个以上。“和/或”,描述关联对象的关联关系,表示可以存在三种关系,例如,A和/或B,可以表示:单独存在A,同时存在A和B,单独存在B的情况,其中A,B可以是单数或者复数。字符“/”一般表示前后关联对象是一种“或”的关系。“以下至少一项(个)”或其类似表达,是指的这些项中的任意组合,包括单项(个)或复数项(个)的任意组合。例如,a,b,或c中的至少一项(个),可以表示:a,b,c,a-b,a-c,b-c,或a-b-c,其中a,b,c可以是单个,也可以是多个。
以及,除非有相反的说明,本申请实施例提及“第一”、“第二”等序数词是用于对多个对象进行区分,不用于限定多个对象的顺序、时序、优先级或者重要程度。例如,第一信息和第二信息,只是为了区分不同的信息,而并不是表示这两种信息的内容、优先级、发送顺序或者重要程度等的不同。
如上介绍了本申请实施例涉及的一些概念,下面介绍本申请实施例的技术特征。
随着社会的发展,现代生活中越来越多的机器向自动化、智能化发展,移动出行用的汽车也不例外,智能汽车正在逐步进入人们的日常生活中。近些年,ADAS在智能汽车中发挥着十分重要的作用,它是利用安装在车上的各式各样的传感器,在汽车行驶过程中随时来感应周围的环境,收集数据,进行静止、移动物体的辨识、侦测与追踪,并结合导航仪地图数据,进行系统的运算与分析,从而预先让驾驶者察觉到可能发生的危险,有效增加汽车驾驶的舒适性和安全性。可以说,真正的无人驾驶是ADAS发展到极致的产物。在无人驾驶架构中,传感层被比作为汽车的“眼睛”,包括车载摄像头等视觉系传感器和车载毫米波雷达、车载激光雷达和车载超声波雷达等雷达系传感器。毫米波雷达由于成本较低、技术比较成熟,率先成为无人驾驶系统主力传感器。目前ADAS已开发出十多项功能,其中自适应巡航、自动紧急制动、变道辅助、或盲点监测等都离不开车载毫米波雷达。
毫米波是指波长介于1~10mm之间的电磁波,所对应的频率范围为30~300GHz。在这个频段,毫米波相关的特性使其非常适合应用于车载领域。带宽大:频域资源丰富,天线副瓣低,有利于实现成像或准成像;波长短:雷达设备体积和天线口径得以减小,重量减 轻;波束窄:在相同天线尺寸下毫米波的波束要比微波的波束窄得多,雷达分辨率高;穿透强:相比于激光雷达和光学系统,更加具有穿透烟、灰尘和雾的能力,可全天候工作。
车载毫米波雷达系统,一般包括振荡器、发射天线、接收天线、混频器、处理器和控制器等装置。如图1所示,为毫米波雷达的工作原理图。振荡器会产生一个频率随时间线性增加的雷达信号,该雷达信号一般是调频连续波。该雷达信号的一部分经过定向耦合器输出至混频器作为本振信号,一部分通过发射天线发射出去,接收天线接收发射出去的雷达信号遇到车辆前方的物体后反射回来的雷达信号,混频器将接收的雷达信号与本振信号进行混频,得到中频信号。中频信号包含了目标物体与该雷达系统的相对距离、速度、以及角度等信息。中频信号经过低通滤波器并经过放大处理后输送到处理器,处理器对接收的信号进行处理,一般是对接收的信号进行快速傅里叶变换,以及频谱分析等,以得到目标物体相对于该雷达系统的距离、速度和角度等信息。最后,处理器可以将得到的信息输出给控制器,以控制车辆的行为。
毫米波雷达的调频连续波波形一般是锯齿波或者三角波,以下以锯齿波为例详细介绍一下毫米波雷达的测距原理,三角波的测距原理与之类似。
如图2所示,线性调频连续波是频率随时间线性变化的信号,如图3所示,调频连续波的周期为T
c,斜率为a
0,带宽为B,其起始频率为b
0。图2所示的一个调频连续波信号也被称为一个线性调频脉冲(chirp)信号。
毫米波雷达的振荡器输出的单周期的调频连续波的等效基带信号可以表示为:

其中A表示等效基带信号的幅度,a
0表示等效基带信号的斜率,b
0表示等效基带信号在Y轴的截距,
 表示等效基带信号的初相,exp表示e的指数函数。由于频率定义为相位相对于时间的变化率。因此,上述等效基带信号的频率为:

公式1.2的图像正如图3所示。
振荡器发出的等效基带信号经过上变频后,由毫米波雷达的发射天线向外辐射,发射信号可表示为:

该信号遇到障碍物后,会反射回来,再被该毫米波雷达接收。发射信号的波形与反射信号的波形的形状相同,只是反射信号的波形相对于发射信号的波形会有一段时延τ,可参考图4。在图4中,回波信号就是反射信号。接收的反射信号可表示为:

对接收的等效基带信号进行下变频后得到的信号为:

其中,A′是振荡器发出的等效基带信号经过发射天线增益、目标反射、传播损耗、接收天线增益后的信号的幅度,τ是从毫米波雷达的发射机发送雷达信号到该毫米波雷达的 接收机接收到回波信号(也就是反射信号),这之间的时延,如图4所示,这个时延是2倍距离/光速。另外在图4中,τ
max表示该毫米波雷达的最大探测距离所对应的回波时延,也就是说,τ
max是在该毫米波雷达与目标物体之间的距离是该毫米波雷达所能探测的最大距离时,该毫米波雷达所接收的反射信号相对于发射信号的时延。τ与目标距离d的关系可以表示为:

其中,c为光速。
该毫米波雷达的混频器将接收信号与本振信号混频,并经过低通滤波器后,输出中频信号,中频信号表示为:

将该中频信号送入该毫米波雷达的处理器进行快速傅里叶变换等处理,可得到中频信号的频率f
IF。
另外,如图4所示,中频信号的频率为发射信号的波形的斜率与时延τ的乘积,即:

因此,该毫米波雷达与目标物体之间的距离d为:

通过上面的推导过程可以看出,发射信号与接收信号之间的频率差(即,中频信号的频率)和时延呈线性关系:目标物体越远,接收反射信号的时间就越晚,那么反射信号和发射信号之间的频率差值就越大。因此,通过判断中频信号的频率的高低就可以确定该雷达与目标物体之间的距离。另外,上述的对雷达信号的处理过程只是示例,对于具体的雷达处理过程不做限制。
随着车载雷达渗透率的提升,车载雷达之间的互干扰越来越严重,将会极大降低雷达探测概率或提升雷达探测的虚警概率,对驾驶安全或舒适性造成不可忽视的影响。
可参考图5,为车载雷达之间相互干扰的示意图。雷达1发出发射信号,并接收该发射信号在目标物体上反射回来的反射信号。在雷达1接收反射信号的同时,雷达1的接收天线也接收到了雷达2的发射信号或者反射信号,那么雷达1所接收的雷达2的发射信号或雷达2的反射信号对于雷达1来说就是干扰信号。
例如,令雷达1为观测雷达,其调频连续波的斜率是a
0,截距是b
0,周期是T
c。雷达2为干扰雷达,其调频连续波的斜率是a
1,截距是b
1,此时假设b
0=b
1。雷达1的最大测距距离对应的回波时延是τ
max(即,在公式1.6中带入雷达的最大探测距离所计算出的时延。例如雷达的最大探测距离为250m,带入公式1.6所算出的时延为1.67μs),到达雷达1的接收机的雷达2的干扰信号的时延是τ
1。考虑雷达发射时刻存在定时误差为Δτ(例如,由于全球卫星定位系统(global positioning system,GPS)的定时误差产生的发射时刻的误差,例如60ns)。其中,雷达检测接收信号的时间区间是τ
max~T
c。
图6、图7为一种可能的虚假中频信号的示意图。若雷达1发送的雷达信号的斜率和雷达2发送的雷达信号的斜率一致,即a
0=a
1,且两者的工作频带有重叠,则会出现虚警。 如图6所示,雷达1向目标物体发射信号,并从目标物接收反射信号,但是在雷达1发射信号和接收到反射信号之间的时间范围内,雷达1的接收天线接收到了雷达2的发射信号或者反射信号(虚线)。雷达1的信号波形与雷达2的信号波形一致且两者的扫频带宽相同,在雷达1的目标回波观察范围内,雷达1接收到了对应频率的虚线所示的信号,则雷达1认为有“目标物体1”存在;雷达1在信号处理的时间区间(τ
max~T
c)内检测到虚线所示的信号和实线所示的反射信号,那么雷达1会把接收到的虚线所示的信号误认为是前方存在的物体的反射信号,此时就会产生虚假的中频信号。雷达1经过快速傅里叶变换后进行频谱分析可以发现两个峰值,如图7所示,每个峰值对应一个目标物体,雷达1认为同时存在“目标物体1”以及“目标物体2”。雷达1误认为前方存在“目标物体1”,而实际上该“目标物体1”是不存在的,这就被称为“ghost”或者“虚警”。虚警产生后会使得自动驾驶汽车在前方并没有物体的情况下减速或急刹,降低了驾驶的舒适度。
图8、图9为一种可能的干扰信号淹没目标信号的示意图。如图8所示,雷达1向目标物体发射信号,并从目标物体接收反射信号。但是在雷达1的目标回波观察范围内,雷达1的接收天线接收到了雷达2的发射信号或者反射信号(虚线)。雷达1的信号波形与雷达2的信号波形在斜率上存在差异,在雷达1在信号检测的时间区间(τ
max~T
c)内,会同时检测到雷达1的反射信号和雷达2的相关信号,在将检测到的雷达2的相关信号与雷达1的反射信号混频之后,会产生一个包含各种频率分量的中频信号,经过快速傅里叶变换后如图9所示,会出现一个干扰平台,使得真正的目标物体的“凸出”程度不够,对检测带来困难,提升了漏检的可能。漏检产生后会使得自动驾驶汽车在前方有物体的情况下,误以为没有物体,不采取减速或制动,造成交通事故,降低车辆行驶的安全性。
具体来说,雷达1的信号波形与雷达2的信号波形在斜率上存在差异,假若雷达1的波形斜率为a
0,雷达2的波形斜率为a
1,那么两个斜率的差异可以分为以下两种情况:
当a
1<a
0时,如图10所示,会产生干扰平台问题,从而导致漏检问题。
当a
1>a
0时,如图11所示,也会产生干扰平台问题,从而导致漏检问题。
这里需要说明的是,本领域技术人员可知,在某一时刻或一段时间接收到的信号,可能为干扰信号,可能为目标物的反射信号,通过时间和发射/反射信号频率的相关变化情况能清楚的体现雷达的探测情况。因此,本申请实施例后续的阐述中,大多以反映发射/反射信号的斜率(单位时间内频率的变化范围)的曲线图来表示雷达之间的互干扰情况。
而如果降低雷达探测概率降低,或雷达探测的虚警概率提升,对驾驶安全或舒适性造成不可忽视的影响。因此,如何降低车载雷达之间的干扰是必须要解决的问题。
为了解决上述问题,在一种可能的解决方案中,可以设置不同雷达具有不同的波形斜率、周期等参数。图12为一种可能的解决方案示意图。如图12所示,雷达1的信号的波形的斜率、发射周期等参数与雷达2的不一致,如此一来,即使雷达1接收到了雷达2的信号,由于其信号的波形不一致,在通过混频器时,即两者的频率在做差时,不会产生恒定频率的中频信号。因为只有恒定频率的中频信号才会在频谱分析中体现为峰值信号,所以该方法能够减小ghost发生的概率。但是,若雷达1接收到了雷达2的信号,经过混频器后,干扰信号落在有效的接收中频带宽内,就会抬升干扰信号的强度。干扰信号水平经过抬升后,会使得原有目标被干扰淹没掉,参见图13。图13为一种可能的漏检结果示意图。产生的后果即为车辆前方有障碍物却没有被检测出来,从而产生漏检,这对车辆行驶 的安全造成了恶劣的影响,尤其是无人驾驶车辆的安全。
图14为又一种可能的解决方案示意图。该方案所采用的技术为雷达波形频率切换(shift)技术。若雷达在其扫频频带检测到有其他雷达产生的干扰后,跳到另一个频带,以防止多雷达之间的干扰。频率切换(shift)技术中频率切换(shift)的间隔可以大于雷达扫频带宽,如图14,这种情况下各雷达波形完全频分,没有重叠情况,但是频率切换(shift)间隔的设置使得频域资源被占用太多,而目前分配给车载雷达的频域资源是有限的。又或者仍然应用频率切换(shift)技术,但是雷达在工作频段检测到有其他雷达产生的干扰后,进行随机频率切换(shift),如图15。图15为再一种可能的解决方案示意图。这种情况下能在一定程度上减弱干扰,但是完全随机化的频率切换(shift)难免会造成频率切换(shift)后的两个雷达的波形在频域上过于接近而导致出现ghost或者干扰信号的强度提升而导致物体被漏检。
鉴于此,提供本申请实施例的技术方案。在本申请实施例中,L个时域范围中的任意两个时域范围的时域起始位置的差值的绝对值可以大于或等于第一阈值以及小于或等于第二阈值,第一阈值是根据至少一个回波时延和至少一个传播时延确定的,例如任意两个时域范围的时域起始位置的差值的绝对值都需要大于或等于至少一个回波时延和至少一个传播时延中的最大值,而在一个时域范围只允许一个雷达探测装置进行发送,这样,一个雷达探测装置发送的雷达信号就不会落到其他雷达探测装置的目标回波观察范围内,而其他雷达探测装置所发送的雷达信号也不会落到第一雷达探测装置的目标回波观察范围内。通过这种方式,可以减小雷达探测装置之间的干扰。
如图16所示,为本申请实施例的一种可能的应用场景示意图。上述应用场景可以为无人驾驶、自动驾驶、智能驾驶、网联驾驶等。雷达探测装置可以安装在机动车辆(例如无人车、智能车、电动车、数字汽车等)、无人机、轨道车、自行车、信号灯、测速装置或网络设备(如各种系统中的基站、终端设备)等等。本申请实施例既适用于车与车之间的雷达探测装置,也适用于车与无人机等其他装置的雷达探测装置,或其他装置之间的雷达探测装置。另外,雷达探测装置可以安装在移动设备上,例如安装在车辆上作为车载雷达探测装置,或者也可以安装在固定的设备上,例如安装在路侧单元(road side unit,RSU)等设备上。本申请实施例对雷达探测装置安装的位置和功能等不做限定。
本申请实施例可以由探测装置来执行,例如执行本申请实施例提供的方法的探测装置可以称为第一探测装置。为阐述方便,本申请实施例下文中多以探测装置为雷达探测装置、雷达探测装置为雷达,例如毫米波雷达,为例,进行实施例的解释和说明。但是本申请实施例不限定探测装置仅为雷达探测装置,也不限制雷达探测装置仅为毫米波雷达或者雷达。进一步,本申请实施例中,在L个时域范围中的相应的时域范围发送雷达信号的多个雷达探测装置,可以有着相同的扫频周期。例如,在该多个时域范围内的第1个时域范围发送雷达信号的为雷达探测装置1,在该多个时域范围内的第2个时域范围发送雷达信号的为雷达探测装置2,那么雷达探测装置1的扫频周期和雷达探测装置2的扫频周期相同。
另外,探测装置所发送的信号可以是无线电信号,如果以探测装置是雷达探测装置为例,那么可以认为探测装置所发送的信号是雷达信号。本申请实施例就以探测装置是雷达探测装置、探测装置所发送的信号是雷达信号为例。
需要说明的是,在L个时域范围内,有多个雷达探测装置在相应的时域范围上发射雷达信号。其中,时域范围可以是指一段连续的时长,雷达探测装置可以在这段连续的时长内 进行一个或多个扫频周期的无线电信号的发送。另外,时域范围也可以称为时域单元、时域资源、时间单元、时间资源或时长等,对于具体的名称不做限制。一个时域范围的长度,可以等于雷达探测装置的发射周期(或称为扫频周期、扫频时长等)。也可以说,L个时域范围中的每个时域范围的时域长度都可以是雷达探测装置的扫频周期。或者,一个时域范围的长度,可以等于雷达探测装置的扫频周期的整数倍。例如,某一时域范围的时长为500个扫频周期,则相应的雷达探测装置在这个时域范围内需要发射500个扫频周期的雷达信号。在一些场景下,L个时域范围的时域长度相同。在另一些场景下,L个时域范围的时域长度可以不完全相同。
另外需要说明的是,在一种可能的情况下,雷达探测装置以一定的发射定时进行雷达信号的发射,但是由于实际通信场景、环境或硬件设备存在的可能的差异,雷达信号的实际发送时刻可能会存在误差,也可以称为信号发射误差。例如,由GPS的精度所带来的误差。又一种可能的情况下,在生产制造过程中,不同的雷达探测装置由于生产制造的差异可能导致在信号发射时出现些许误差。在其他情况下,还可能存在其它原因导致的误差。对于上述所有可能的误差,本申请实施例所提供的方法在具体实现时都可以考虑。或者,本申请实施例也可以忽略这些误差,按照统一的标准和发射定时,进行方案阐述。需要明确的是,本申请实施例在阐述技术方案时,上述误差无论是被考虑还是被忽略,都不实质影响本申请实施例的实现及有益效果。
下面结合附图介绍本申请实施例提供的技术方案。
本申请实施例提供一种雷达信号发送方法,请参见图17A,为该方法的流程图。在下文的介绍过程中,以该方法应用于图16所示的网络架构为例。图17A所示的实施例提供的方法,可以由图16所示的网络架构中的雷达探测装置来执行,例如将该雷达探测装置称为第一雷达探测装置。另外在下文的介绍过程中,雷达探测装置所发送的信号,均可以是雷达信号,自然的,所接收的回波信号也可以是雷达信号。
S1701、第一雷达探测装置确定第一时域范围。
其中,所述第一时域范围为L个时域范围中的时域范围,所述L为大于1的正整数。
其中,L个时域范围中的任一个时域范围与其它L-1个时域范围中的至少一个时域范围部分重叠,L个时域范围中任两个时域范围的时域起始位置的差值的绝对值大于或等于第一阈值且小于或等于第二阈值。第一阈值是根据至少一个回波时延和至少一个传播时延确定的,至少一个回波时延包含第一雷达探测装置的最大探测距离对应的回波时延(例如称为第一回波时延),至少一个传播时延包括第一雷达探测装置发送的第一雷达信号对应的传播时延(例如称为第一传播时延)。这里的“L”,可以是预先定义或者配置的,也可以是根据预设的规则确定的。例如,对于一个雷达探测装置来说,“L”可以体现为在一个扫频周期内存在L个候选的时域格点,每个时域格点与一定的时长构成一个时域范围。所述时域格点可以为时域范围的起始位置或者结束位置,或者是时域范围的中间位置等。这里不做具体限定。由于雷达探测装置会工作在一定的时长内,因此本申请以“时域范围”进行方案的阐述和解释。技术上,时域范围可以通过时域格点以及时长来定义,S1701可以替换为“S1701、第一雷达探测装置确定第一时域格点”,所述第一探测装置根据所述第一时域格点确定第一时域范围。进一步,所述第一时域格点为L个时域格点中的一个。
在本申请实施例中,该L个时域范围可以称为一个时域范围的集合。当然,该L个时域范围、该L个时域范围内的每个时域范围,也可以定义为其他名称,无论其名称如何定 义,L个时域范围指代的是一个较大粒度的时间长度,每个时域范围指代的是一个较小粒度的时间长度。
其中,L个时域范围中的任一个时域范围与其它L-1个时域范围中的至少一个时域范围部分重叠(或者说,不完全重叠)。所谓的两个时域范围完全重叠,是指这两个时域范围完全相同,例如两个时域范围的时域起始位置相同且时域结束位置相同;或者,两个时域范围完全重叠,是指两个时域范围中一个时域范围完全包含在另一个时域范围内。而不完全重叠,就是指两个时域范围有交集,但两个时域范围不完全相同,例如两个时域范围的时域起始位置相同而时域结束位置不同,或者两个时域范围的时域起始位置不同而时域结束位置相同,或者两个时域范围的时域起始位置不同且时域结束位置不同。通过这种设计,能够实现避免完全时分的资源设计,节约时域资源;又能够适当的调整雷达探测装置在时域上的分布密度,在保证高性能通信的基础上,使得尽量多的雷达探测装置在一定时域长度内进行雷达信号的发射。
上述多个时域范围部分重叠的设计方式,可以避免将多个雷达探测装置的扫频周期完全在时域上分开而造成的时域资源浪费,可以有效利用时域资源,以较低的时域资源代价实现较高的抗干扰性能,同时又可以支持更多数目的雷达探测装置通信。
进一步地,L个时域范围中任两个时域范围的时域起始位置的差值的绝对值大于或等于第一阈值且小于或等于第二阈值,可以包括如下两种情况。
例如,这L个时域范围的时域起始位置在时域上是等间距划分的。在这个例子中,这L个时域范围中任意两个在时域上“相邻”的时域范围的时域起始位置的差值的绝对值例如等于F,则任意两个时域上“不相邻”的时域范围的时域起始位置的差值的绝对值可以等于F的X倍,X为大于1的正整数。
再例如,这L个时域范围的时域起始位置在时域上不是等间距划分的。在这个例子中,这L个时域范围中的哪两个时域范围的时域起始位置的差值的绝对值最小,则就令这两个时域范围的时域起始位置的差值的绝对值等于F,除了这两个时域范围之外,L个时域范围中的其他的任意两个时域范围的时域起始位置的差值的绝对值都可以大于F。
下面结合图17B进行举例说明。
图17B示意了L等于3时的一种可选案例。L等于3时,3个时域范围可以分别称为第1个时域范围、第2个时域范围、第3个时域范围。这3个时域范围中,任意一个时域范围与其它2个时域范围部分重叠。在图17B中,第1个时域范围与第2个时域范围的重叠区域标记为重叠区域1,第1个时域范围与第3个时域范围的重叠区域标记为重叠区域3,第2个时域范围与第3个时域范围的重叠区域标记为重叠区域2。在图17B中,3个时域范围中任两个时域范围的时域起始位置的差值的绝对值大于或等于第一阈值及小于或等于第二阈值。其中,第1个时域范围的时域起始位置与第2个时域范围的起始位置的差值的绝对值为间隔区域1的长度,第2个时域范围的时域起始位置与第3个时域范围的起始位置的差值的绝对值为间隔区域2的长度,第3个时域范围的时域起始位置与第1个时域范围的起始位置的差值的绝对值为间隔区域3的长度。本申请实施例中,间隔区域1的长度、间隔区域2的长度、间隔区域3的长度均大于或等于第一阈值及小于或等于第二阈值。
需要说明的是,假如该L个时域范围按照时域从前到后的顺序,依次包括第1个时域范围、第2个时域范围、第3个时域范围,称第1个时域范围与第2个时域范围的时域起 始位置的差值的绝对值为第一绝对值,称第2个时域范围与第3个时域范围的时域起始位置的差值的绝对值为第二绝对值,那么第一绝对值可以等于第二绝对值,也可以不等于第二绝对值。但是第一绝对值和第二绝对值都大于或等于第一阈值及小于或等于第二阈值。
第一雷达探测装置可以是需要发送雷达信号的雷达探测装置,因此第一雷达探测装置可以从L个时域范围里选择第一时域范围来发送雷达信号。例如还有第二雷达探测装置,也可以是需要发送雷达信号的雷达探测装置,例如第二雷达探测装置也可以从L个时域范围里选择相应的时域范围来发送雷达信号。其中,时域范围和雷达探测装置应该是一一对应的关系,也就是说,第二雷达探测装置可以从L个时域范围里选择第二时域范围来发送雷达信号,第二时域范围和第一时域范围不是同一个时域范围。但是还有一种可能,第二雷达探测装置在需要选择时域范围时,可能L个时域范围都已被占用,那么第二雷达探测装置可以从已被占用的L个时域范围内选择一个时域范围来进行发送。
另外,第一雷达探测装置和第二雷达探测装置的类别可以不同,或者也可以相同。例如共有N类雷达探测装置,第一雷达探测装置属于N类雷达探测装置中的第一类雷达探测装置,第二雷达探测装置属于N类雷达探测装置中的第二类雷达探测装置。其中,雷达探测装置可以有多种参数,例如一种参数为雷达探测装置的最大探测距离对应的回波时延,例如另一种参数为雷达探测装置所发送的雷达信号的传播时延,那么对于两个雷达探测装置来说,只要这两种参数中的至少一种参数的取值不同,就表明这两个雷达探测装置的类别不同。例如,第一雷达探测装置的最大探测距离对应的回波时延和第二雷达探测装置的最大探测距离对应的回波时延不同,表明第一雷达探测装置和第二雷达探测装置的类别不同;或者,第一雷达探测装置所发送的雷达信号的传播时延和第二雷达探测装置所发送的雷达信号的传播时延不同,表明第一雷达探测装置和第二雷达探测装置的类别不同;或者,第一雷达探测装置的最大探测距离对应的回波时延和第二雷达探测装置的最大探测距离对应的回波时延不同,且第一雷达探测装置所发送的雷达信号的传播时延和第二雷达探测装置所发送的雷达信号的传播时延不同,表明第一雷达探测装置和第二雷达探测装置的类别不同;或者,第一雷达探测装置的最大探测距离对应的回波时延和第二雷达探测装置的最大探测距离对应的回波时延相同,且第一雷达探测装置所发送的雷达信号的传播时延和第二雷达探测装置所发送的雷达信号的传播时延相同,表明第一雷达探测装置和第二雷达探测装置的类别相同。
所述的至少一个回波时延除了包括第一回波时延之外,还可以包括其他的雷达探测装置的回波时延,可以理解为,至少一个回波时延可以对应于至少一个雷达探测装置。例如,第二雷达探测装置的最大探测距离对应的回波时延可以称为第二回波时延,第二回波时延可以包括在所述的至少一个回波时延中。第二回波时延可以等于第一回波时延,也可以不等于第一回波时延。如果第二回波时延不等于第一回波时延,就表明第二雷达探测装置和第一雷达探测装置的类别不同,在这种情况下,第二雷达探测装置所发送的雷达信号(例如称为第二雷达信号)的传播时延可以等于第一传播时延,也可以不等于第一传播时延,不再做限制。
所述的至少一个传播时延除了包括第一传播时延之外,还可以包括其他的雷达探测装置对应的雷达信号(或者说,发送的雷达信号)的传播时延,可以理解为,至少一个传播时延可以对应于至少一个雷达探测装置。例如,第三雷达探测装置所发送的雷达信号(例如称为第三雷达信号)的传播时延例如称为第二传播时延,第二传播时延可以包括在所述 的至少一个传播时延中。第二传播时延可以等于第一传播时延,也可以不等于第一传播时延。如果第二传播时延不等于第一传播时延,就表明第三雷达探测装置和第一雷达探测装置的类别不同,在这种情况下,第三雷达探测装置所发送的第三雷达信号的回波时延可以等于第一回波时延,也可以不等于第一回波时延,不再做限制。
第二雷达探测装置和第三雷达探测装置可以是同一个雷达探测装置,或者也可以是不同的雷达探测装置。
雷达探测装置对应的回波时延是指,雷达探测装置在进行探测时,雷达探测装置发出雷达信号的时刻,与所发出的雷达信号在到达目标物体后被反射后的反射信号被该雷达探测装置接收的时刻,这两个时刻之间的时间差。而雷达探测装置的最大探测距离对应的回波时延是指,雷达探测装置在进行探测时,如果所探测的目标物体与雷达探测装置之间的距离是雷达探测装置支持的最大探测距离,那么雷达探测装置发出雷达信号的时刻,与所发出的雷达信号在到达目标物体后被反射后的反射信号被该雷达探测装置接收的时刻,这两个时刻之间的时间差。
第一阈值可以根据至少一个回波时延和至少一个传播时延确定。例如,根据至少一个回波时延和至少一个传播时延可以确定多个第一子阈值,多个第一子阈值中的最大值就可以作为第一阈值。另外,第二阈值也可以根据至少一个回波时延和至少一个传播时延确定。例如,根据至少一个回波时延和至少一个传播时延可以确定多个第二子阈值,多个第二子阈值中的最小值就可以作为第二阈值。这里需要说明的是,多个第一子阈值和多个第二子阈值均是根据至少一个回波时延和至少一个传播时延确定的,具体的确定方式可以不同。
例如共包括N个雷达探测装置,那么可以根据每两个雷达探测装置求取第一子阈值,也就是说,针对每两个雷达探测装置,都可以求得一个第一子阈值,再取所求得的多个第一子阈值的最大值作为第一阈值。例如,根据N个雷达探测装置,共可以确定
 个第一子阈值,
 个第一子阈值中的每个第一子阈值是根据N个雷达探测装置中的两个雷达探测装置的最大探测距离对应的回波时延,以及这两个雷达探测装置发送的雷达信号的传播时延确定的,那么,第一阈值就可以是
 个第一子阈值中的最大值。
另外,可以根据每两个雷达探测装置求取第二子阈值,也就是说,针对每两个雷达探测装置,都可以求得一个第二子阈值,再取所求得的多个第二子阈值的最小值作为第二阈值。例如,根据N个雷达探测装置,共可以确定
 个第二子阈值,
 个第二子阈值中的每个第二子阈值是根据N个雷达探测装置中的两个雷达探测装置的最大探测距离对应的回波时延,以及这两个雷达探测装置发送的雷达信号的传播时延确定的,那么,第二阈值就可以是
 个第二子阈值中的最小值。
N个雷达探测装置可以均是需要发送雷达信号的雷达探测装置,或者说,可以均是需要从多个时域范围内选择时域范围以发送雷达信号的雷达探测装置,或者,N个雷达探测装置中的部分雷达探测装置也可能无需从多个时域范围内选择时域范围。本申请实施例对于N个雷达探测装置究竟包括哪些不做限制。
在如上的方式中,不区分雷达探测装置的类别,只要是两个不同的雷达探测装置,都可以根据这两个雷达探测装置来求得第一子阈值或第二子阈值,而这两个雷达探测装置的类别可能不同,也可能相同。
或者还有一种方式,可以区分不同类别的雷达探测装置,可以根据不同类别的雷达探测装置来求得第一子阈值或第二子阈值,也可以根据相同类别的雷达探测装置来求得第一 子阈值或第二子阈值。
例如共包括N类雷达探测装置,那么可以根据每两类雷达探测装置求取第一子阈值,也就是说,针对每两类雷达探测装置,都可以求得一个第一子阈值,再取所求得的多个第一子阈值的最大值作为第一阈值。也可以根据每一类雷达探测装置求取第一子阈值,也就是说,针对每类雷达探测装置,都可以求得一个第一子阈值,再取所求得的多个第一子阈值的最大值作为第一阈值。例如,根据N类雷达探测装置,共可以确定
 个第一子阈值,
 个第一子阈值中的一个第一子阈值是根据N类雷达探测装置中的两类雷达探测装置的最大探测距离对应的回波时延,以及这两类雷达探测装置发送的雷达信号的传播时延确定的,或是根据N类雷达探测装置中的一类雷达探测装置的最大探测距离对应的回波时延,以及这类雷达探测装置发送的雷达信号的传播时延确定的,那么,第一阈值就可以是
 个第一子阈值中的最大值。
另外,可以根据每两类雷达探测装置求取第二子阈值,也就是说,针对每两类雷达探测装置,都可以求得一个第二子阈值,再取所求得的多个第二子阈值的最小值作为第二阈值。也可以根据每一类雷达探测装置求取第二子阈值,也就是说,针对每类雷达探测装置,都可以求得一个第二子阈值,再取所求得的多个第二子阈值的最小值作为第二阈值。例如,根据N类雷达探测装置,共可以确定
 个第二子阈值,
 个第二子阈值中的每个第二子阈值是根据N类雷达探测装置中的两类雷达探测装置的最大探测距离对应的回波时延,以及这两类雷达探测装置发送的雷达信号的传播时延确定的,或是根据N类雷达探测装置中的一类雷达探测装置的最大探测距离对应的回波时延,以及这类雷达探测装置发送的雷达信号的传播时延确定的,那么,第二阈值就可以是
 个第二子阈值中的最小值。
或者还有一种方式,可以区分不同类别的雷达探测装置,可以只根据不同类别的雷达探测装置来求得第一子阈值或第二子阈值,而如果两个雷达探测装置的类别相同,则不根据这两个雷达探测装置来求得第一子阈值或第二子阈值。
例如共包括N类雷达探测装置,那么可以根据每两类雷达探测装置求取第一子阈值,也就是说,针对每两类雷达探测装置,都可以求得一个第一子阈值,再取所求得的多个第一子阈值的最大值作为第一阈值。例如,根据N类雷达探测装置,共可以确定
 个第一子阈值,
 个第一子阈值中的每个第一子阈值是根据N类雷达探测装置中的两类雷达探测装置的最大探测距离对应的回波时延,以及这两类雷达探测装置发送的雷达信号的传播时延确定的,那么,第一阈值就可以是
 个第一子阈值中的最大值。
另外,可以根据每两类雷达探测装置求取第二子阈值,也就是说,针对每两类雷达探测装置,都可以求得一个第二子阈值,再取所求得的多个第二子阈值的最小值作为第二阈值。例如,根据N类雷达探测装置,共可以确定
 个第二子阈值,
 个第二子阈值中的每个第二子阈值是根据N类雷达探测装置中的两类雷达探测装置的最大探测距离对应的回波时延,以及这两类雷达探测装置发送的雷达信号的传播时延确定的,那么,第二阈值就可以是
 个第二子阈值中的最小值。
其中,根据一类雷达探测装置进行计算时,只需根据一类雷达探测装置中的任一个雷达探测装置进行计算即可。N类雷达探测装置可以均是需要发送雷达信号的雷达探测装置,或者说,可以均是需要从多个时域范围内选择时域范围以发送雷达信号的雷达探测装置,或者,N类雷达探测装置中的部分类别的雷达探测装置也可能无需从多个时域范围内选择 时域范围,例如N类雷达探测装置可以包括目前市场上所有的类别的雷达探测装置。本申请实施例对于N类雷达探测装置究竟包括哪些不做限制。
本申请实施例中,对于第一阈值(或者说,第一子阈值)或第二阈值(或者说,第二子阈值),可以有不同的确定方法。在下面的介绍过程中,以第一阈值是根据第四雷达探测装置和第五雷达探测装置计算得到的为例。也就是说,第一阈值是多个第一子阈值中的最大值,而最终选择的这个最大值,例如是根据第四雷达探测装置和第五雷达探测装置计算得到的。其中,第四雷达探测装置或第五雷达探测装置例如为第一雷达探测装置,或者,第四雷达探测装置和第五雷达探测装置都不是第一雷达探测装置。但因为第一阈值是多个第一子阈值中的最大值,而第一雷达探测装置的参数(例如第一回波时延和第一传播时延)也参与了对于多个第一子阈值中的部分第一子阈值的计算过程,因此,即使第四雷达探测装置和第五雷达探测装置都不是第一雷达探测装置,也依然可以认为,第一阈值是根据至少一个回波时延和至少一个传播时延确定的,至少一个回波时延包含第一回波时延,至少一个传播时延包括第一传播时延。
另外,第一子阈值或第二子阈值的确定也与雷达探测装置的位置有关。例如,雷达探测装置是可移动的雷达探测装置,例如车载雷达探测装置(例如车载雷达),和雷达探测装置是固定位置的雷达探测装置(例如设置在RSU上的雷达探测装置),在这两种情况下,所确定的第一子阈值或第二子阈值可能有所不同。下面分别介绍。在下面的介绍过程中,以第四雷达探测装置和第五雷达探测装置参与计算为例,也就是说,下面所介绍的过程,可以认为是在确定第一阈值和第二阈值,也可以认为是在确定第一子阈值和第二子阈值。
一、雷达探测装置是可移动的雷达探测装置,例如车载雷达。
在这种情况下,可以根据第四雷达探测装置的最大探测距离对应的回波时延、第五雷达探测装置的最大探测距离对应的回波时延、第四雷达探测装置发送的雷达信号的最大传播时延(或者说,第四雷达探测装置的发射信号的最大传播时延)、以及第五雷达探测装置发送的雷达信号的最大传播时延(或者说,第五雷达探测装置的发射信号的最大传播时延),确定一个第一子阈值。也可以根据第四雷达探测装置的最大探测距离对应的回波时延、第五雷达探测装置的最大探测距离对应的回波时延、第四雷达探测装置发送的雷达信号的最大传播时延(或者说,第四雷达探测装置的发射信号的最大传播时延)、以及第五雷达探测装置发送的雷达信号的最大传播时延(或者说,第五雷达探测装置的发射信号的最大传播时延),确定一个第二子阈值。
例如,最终的第一阈值是根据第四雷达探测装置和第五雷达探测装置所确定的第一子阈值,最终的第二阈值是根据第六雷达探测装置和第七雷达探测装置所确定的第二子阈值。也就是说,第二阈值是根据第六雷达探测装置的最大探测距离对应的回波时延、第七雷达探测装置的最大探测距离对应的回波时延、第六雷达探测装置发送的雷达信号的最大传播时延、以及第七雷达探测装置发送的雷达信号的最大传播时延所确定的第二子阈值。其中,第四雷达探测装置和第六雷达探测装置可以是同一个探测装置,或者也可以是不同的探测装置;第五雷达探测装置和第七雷达探测装置可以是同一个探测装置,或者也可以是不同的探测装置。
接下来,以根据第四雷达探测装置和第五雷达探测装置进行计算为例,介绍如何得到第一子阈值和第二子阈值。需要说明的是,如果根据其他的雷达探测装置来进行计算,例如根据第六雷达探测装置和第七雷达探测装置来进行计算,则计算过程也是跟如下的过程 类似的。下文仅是示例性以第一阈值是根据第四雷达探测装置和第五雷达探测装置得到的第一子阈值、第二阈值是根据第四雷达探测装置和第五雷达探测装置得到的第二子阈值进行方案的说明。
其中,雷达信号的最大传播时延是根据当前的雷达探测装置本身的属性或参数确定的。详细来说,另一雷达信号经历一定的传播时延后会被当前的雷达探测装置接收到,经过所述的传播时延后,如果干扰信号的功率大于当前的雷达探测装置的接收机的灵敏度,则干扰信号会对当前的雷达探测装置产生干扰,而如果干扰信号的功率不大于当前的雷达探测装置的接收机的灵敏度,则干扰信号不会对当前的雷达探测装置产生干扰,干扰信号会被处理为噪声。那么,经过传播时延后,干扰信号的功率如果等于当前的雷达探测装置接收机的灵敏度,则发射该干扰信号的雷达探测装置与当前的雷达探测装置之间的距离,称为干扰最大容忍距离,该传播时延称为最大传播时延。
其中,第四雷达探测装置的最大探测距离对应的回波时延和第五雷达探测装置的最大探测距离对应的回波时延,可以相同也可以不同;第四雷达探测装置发送的雷达信号的最大传播时延和第五雷达探测装置发送的雷达信号的最大传播时延,可以相同也可以不同。第四雷达探测装置和第五雷达探测装置可以是同一类别的雷达探测装置,或者也可以是不同类别的雷达探测装置。
以第四雷达探测装置发送的雷达信号在时间上早于第五雷达探测装置发送的雷达信号为例,本申请实施例在设置时域范围之间的间距时,可以考虑以下几条:
(1)若第四雷达探测装置和第五雷达探测装置之间的距离很近,则第四雷达探测装置和第五雷达探测装置的发送时刻之间至少需要间隔τ
max1才能保证这两个雷达探测装置之间不会相互干扰,τ
max1表示第四雷达探测装置的最大探测距离所对应的回波时延;
(2)若第四雷达探测装置和第五雷达探测装置之间的距离大于τ
max1所对应的距离,则第四雷达探测装置发送的雷达信号在经历传播时延
 后的信号不能落在第五雷达探测装置的目标回波观察范围内;
(3)第五雷达探测装置的发射信号在经历传播时延
 后,也不能落在第四雷达探测装置的下一个周期的有效检测区域内。也就是说,对于一个雷达探测装置来说,可能是周期性发送信号以及周期性接收信号的,那么第五雷达探测装置的发射信号在经历传播时延
 后的信号,也不能被第四雷达探测装置所接收。综合如上的几条可以得出:


其中,公式2.1也可以看做是两个公式,例如,

 可以认为是第一公式,用于确定第一阈值,
 可以认为是第五公式,用于确定第二阈值。
确定第一阈值的公式和确定第二阈值的公式可以合并为一个公式,例如公式2.1,那 么可以一并确定第一阈值和第二阈值;或者,确定第一阈值的公式和确定第二阈值的公式也可以单独存在,可以分别确定第一阈值和第二阈值。
公式2.1中,
 表示第四雷达探测装置的最大探测距离所对应的回波时延,
 表示第五雷达探测装置的最大探测距离所对应的回波时延。
 表示第四雷达探测装置发送的雷达信号的最大传播时延,因此在公式2.1中,
 也可以表示为

 表示第五雷达探测装置发送的雷达信号的最大传播时延,因此在公式2.1中,
 也可以表示为
 a
1表示第四雷达探测装置发送的雷达信号的斜率,a
2表示第五雷达探测装置发送的雷达信号的斜率。在本申请实施例中,斜率的绝对值可以表示单位时间内的频率变化量(或者,表示单位时间内的频率变化范围),所以也可以认为,a
1表示第四雷达探测装置发送的雷达信号在单位时间内的频率变化量,a
2表示第五雷达探测装置发送的雷达信号在单位时间内的频率变化量。在后文中为了便于理解,依然描述为,a
1表示第四雷达探测装置发送的雷达信号的斜率,a
2表示第五雷达探测装置发送的雷达信号的斜率。需要理解的是,本申请实施例中的a
1可以表示斜率的绝对值,或者也可以表示斜率,如果a
1表示斜率,则a
1的取值可能为正,也可能为负。同理,a
2可以表示斜率的绝对值,或者也可以表示斜率,如果a
2表示斜率,则a
2的取值可能为正,也可能为负。Δ
t表示L个时域范围中任两个时域范围的时域起始位置的差值的绝对值。T
c表示第四雷达探测装置的扫频周期。其中,因为第四雷达探测装置和第五雷达探测装置都是可移动的雷达探测装置,因此在公式2.1中带入的是这两个雷达探测装置发送的雷达信号的最大的传播时延,而不是这两个雷达探测装置的发送的雷达信号实际的传播时延。
可参考图18,为按照如上方法所确定的第四雷达探测装置的时域范围和第五雷达探测装置的时域范围的示意图。图18中,实线都表示第四雷达探测装置的信号,虚线都表示第五雷达探测装置的信号(竖直的三条虚线除外),B表示第四雷达探测装置的扫频带宽。根据要求可知,第五雷达探测装置发出信号的时刻至少需要晚于第四雷达探测装置的最大探测距离对应的回波时延(图18中,从左往右的第一条实线表示第四雷达探测装置在一个周期的发射信号,从左往右的第二条实线表示该发射信号的反射信号,也就是回波信号,从左往右的第三条实线表示该发射信号经历最大传播时延
 后的信号),以及要晚于第四雷达探测装置发送的雷达信号的最大传播时延,这样第四雷达探测装置的发射信号才不会被第五雷达探测装置当做接收信号所接收。因此有,


另外还需要保证,第五雷达探测装置的发射信号在带宽B的范围内不会落到第四雷达探测装置的目标回波观察范围内,也就是说,使得第五雷达探测装置的发射信号在带宽B 的范围内不会与第四雷达探测装置的目标回波观察范围相交,当然也要保证第四雷达探测装置的发射信号在带宽B的范围内不会落到第五雷达探测装置的目标回波观察范围内。因此有,

 而且,a
2需要满足以下的约束,如上的公式才能对第五雷达探测装置的扫频周期没有限制:

综合如上的三个公式,可以得到公式2.1。在图18中可以看到,两个雷达探测装置的发射信号彼此都不会落在对方的目标回波观察范围内,不会给对方造成干扰。另外,图18是以第四雷达探测装置的信号作为基准,要使得第五雷达探测装置的信号满足相应的需求以使得两个雷达探测装置之间不会相互干扰,因此在将公式2.1应用于图18时,T
c可以是第四雷达探测装置的扫频周期。
以第四雷达探测装置和第五雷达探测装置均为车载雷达为例。例如,第四雷达探测装置的扫频带宽为250MHz,扫频周期为Tc为27.8μs,最大探测距离250m,对应的最大中频频率为15MHz。第五雷达探测装置发送的雷达信号的斜率(对于一个雷达探测装置来说,发射信号(也就是所发送的雷达信号)的斜率、反射信号的斜率和发射信号经历传播时延后的信号的斜率都相同)为第四雷达探测装置发送的雷达信号的斜率的1.2倍,第五雷达探测装置的最大探测距离也为250m,多雷达间信号的最大传播时延为2μs(例如第四雷达探测装置发射的雷达信号经过600米的传播后,到达第五雷达探测装置接收机处的信号功率为-115dBm,等于第五雷达探测装置的接收机灵敏度,故第四雷达探测装置的最大传播时延是2μs)。根据最大探测距离为250m可计算出

带入公式2.1可得,

 即为6.7μs≤Δ
t≤25.7μs。例如取L个时域范围中的任意两个时延范围的时域起始位置的差值的绝对值为6.7μs,则在27.8μs的扫频周期下,可以支持的互不干扰的雷达探测装置的数量为
 基于以上分析,在该场景下L=4。
可参考图19,为多个雷达所在的时域范围的一种排布示意图。在图20中,较粗的实线都代表相应的雷达的发射信号,虚线表示相应的雷达的反射信号(回波信号),较细的实线表示相应的雷达的发射信号在经历传播时延后的信号。显然的,时域范围之间的间距越小,在相同的扫频时长下所排布的时域范围就越多。雷达探测装置和时域范围可以是一一对应的关系,因此在本申请的各个实施例中,通过将时域范围的间距取所求得的范围的最小值,可以容纳更多的雷达探测装置。
还有一种较为特殊的情况,就是第四雷达探测装置发送的雷达信号的斜率和第五雷达 探测装置发送的雷达信号的斜率相同,那么,公式2.1可以变形为:

其中,公式2.2也可以看做是两个公式,例如,
 可以认为是第二公式,用于确定第一阈值,
 可以认为是第六公式,用于确定第二阈值。
确定第一阈值的公式和确定第二阈值的公式可以合并为一个公式,例如公式2.2,那么可以一并确定第一阈值和第二阈值;或者,确定第一阈值的公式和确定第二阈值的公式也可以单独存在,可以分别确定第一阈值和第二阈值。
可参考图20,为按照如上方法所确定的第四雷达探测装置的时域范围和第五雷达探测装置的时域范围的示意图。图20中,实线都表示第四雷达探测装置的信号,虚线都表示第五雷达探测装置的信号(竖直的三条虚线除外),B表示第四雷达探测装置的扫频带宽。根据要求可知,第五雷达探测装置发出信号的时刻至少需要晚于第四雷达探测装置的最大探测距离对应的回波时延(图20中,从左往右的第一条实线表示第四雷达探测装置在一个周期的发射信号,从左往右的第二条实线表示该发射信号的反射信号,也就是回波信号,从左往右的第三条实线表示该发射信号经历最大传播时延
 后的信号),以及要晚于第四雷达探测装置发送的雷达信号的最大传播时延,这样第四雷达探测装置的发射信号才不会被第五雷达探测装置当做接收信号所接收。因此有,

 而因为第四雷达探测装置发送的雷达信号的斜率和第五雷达探测装置发送的雷达信号的斜率相同,因此不用考虑两个雷达探测装置的波形会相交的情况,那么
 就是公式2.2。在图20中可以看到,两个雷达探测装置的发射信号彼此都不会落在对方的目标回波观察范围内,不会给对方造成干扰。
另外,图20是以第四雷达探测装置的信号作为基准,要使得第五雷达探测装置的信号满足相应的需求以使得两个雷达探测装置之间不会相互干扰,因此在将公式2.2应用于图20时,T
c可以是第四雷达探测装置的扫频周期。
以第四雷达探测装置和第五雷达探测装置均为车载远程雷达(long range radar,LRR)、且第四雷达探测装置的参数和第五雷达探测装置的参数相同为例。例如,第四LRR的扫频带宽为250MHz,扫频周期Tc为27.8μs,最大探测距离为250m,对应的最大的中频频率为15MHz,最大传播时延为2μs(例如第四LRR的雷达信号经过600米的传播后,到达第五LRR接收机处的信号功率为-115dBm,等于第五LRR的接收机灵敏度,故第四LRR的 最大传播时延是2μs)。因为第四LRR的参数和第五LRR的参数相同,因此如上的参数是对应于第四LRR的,也是对应于第五LRR的。根据最大探测距离为250m可计算出

带入公式2.2可得,max(1.67,2)≤Δ
t≤27.8-max(1.67,2),即为2μs≤Δ
t≤25.8μs。例如取L个时域范围中的任意两个时域范围的时域起始位置的差值的绝对值为2μs,则在27.8μs的扫频周期下,可以支持的互不干扰的LRR的数量为

多个LRR所在的时域范围的一种排布示意图可继续参考图19。另外,考虑LRR可以使用76~77GHz的1GHz带宽,LRR的扫频带宽为250MHz,所以可以频分出4个互不干扰的频域资源供LRR使用,可参考图21,这4个频域资源分别为图21中的76GHz~76.25GHz、76.25GHz~76.50GHz、76.50GHz~76.70GHz、以及76.70GHz~77GHz。其中,在每个频域资源上均可以设置多个时域范围。这样,在76~77GHz的1GHz带宽内,可以总共支持4*13=52组互不干扰的雷达信号,也就是可以支持52个LRR。
再例如,在公式2.2的基础上,如果第四雷达探测装置的最大探测距离对应的回波时延等于第五雷达探测装置的最大探测距离对应的回波时延,且第四雷达探测装置发送的雷达信号的最大传播时延等于第五雷达探测装置发送的雷达信号的最大传播时延,例如第四雷达探测装置和第五雷达探测装置是同一类型的雷达探测装置。那么,公式2.1还可以变形为:
max(τ
max,Δ
p)≤Δ
t≤T
c-max(τ
max,Δ
p) (公式2.2-1)
其中,公式2.2-1也可以看做是两个公式,例如,max(τ
max,Δ
p)≤Δ
t可以认为是第二公式,用于确定第一阈值,Δ
t≤T
c-max(τ
max,Δ
p)可以认为是第六公式,用于确定第二阈值。其中,τ
max表示第四雷达探测装置的最大探测距离对应的回波时延,也表示第五雷达探测装置的最大探测距离对应的回波时延,Δ
p表示第四雷达探测装置发送的雷达信号的最大传播时延,也表示第五雷达探测装置发送的雷达信号的最大传播时延。可见,如果两个雷达探测装置相应的参数相同,则只需根据其中一个雷达探测装置的参数计算第一阈值或第二阈值即可。
确定第一阈值的公式和确定第二阈值的公式可以合并为一个公式,例如公式2.2-1,那么可以一并确定第一阈值和第二阈值;或者,确定第一阈值的公式和确定第二阈值的公式也可以单独存在,可以分别确定第一阈值和第二阈值。
以第四雷达探测装置和第五雷达探测装置均为车载雷达为例。例如,第四雷达探测装置的扫频带宽为250MHz,扫频周期为Tc为27.8μs,最大探测距离250m,对应的最大中频频率为15MHz,多雷达间信号的最大传播时延为2μs(例如第四雷达探测装置发射的雷达信号经过600米的传播后,到达第五雷达探测装置接收机处的信号功率为-115dBm,等于第五雷达探测装置的接收机灵敏度,故第四雷达探测装置的最大传播时延是2μs)。根据 最大探测距离为250m可计算出

带入公式2.2-1可得,max(1.67,2)≤Δ
t≤27.8-max(1.67,2),即为2μs≤Δ
t≤25.8μs。例如取L个时域范围中的任意两个时延范围的时域起始位置的差值的绝对值为2μs,则在27.8μs的扫频周期下,可以支持的互不干扰的雷达探测装置的数量为

如上的公式2.1、公式2.2和公式2.2-1并未考虑雷达探测装置之间的同步误差,而不同的雷达探测装置对于时间的理解可能存在不一致的情况,例如第四雷达探测装置认为一个时刻是10:00:00,而第五雷达探测装置可能认为该时刻是10:00:02,因此这两个雷达探测装置之间就会存在同步误差。如果考虑两个雷达探测装置之间的同步误差,那么第一阈值的确定方法会有所不同。例如可以根据至少一个传播时延、至少一个回波时延、以及第一信息来确定第一阈值,可以根据至少一个传播时延、至少一个回波时延、以及第一信息来确定第二子阈值。
如果以第四雷达探测装置和第五雷达探测装置为例,就是可以根据第四雷达探测装置的最大探测距离对应的回波时延、第五雷达探测装置的最大探测距离对应的回波时延、第四雷达探测装置所发送的雷达信号的最大传播时延、第五雷达探测装置所发送的雷达信号的最大传播时延、以及第一信息来确定第一阈值。同理,如果以第四雷达探测装置和第五雷达探测装置为例,就是可以根据第四雷达探测装置的最大探测距离对应的回波时延、第五雷达探测装置的最大探测距离对应的回波时延、第四雷达探测装置所发送的雷达信号的最大传播时延、第五雷达探测装置所发送的雷达信号的最大传播时延、及第一信息来确定第二子阈值。
其中,第一信息可以包括时间余量,或,包括两个雷达探测装置之间的同步误差,或,包括时间余量和两个雷达探测装置之间的同步误差之和。例如,以第四雷达探测装置和第五雷达探测装置参与计算,那么第一信息就可以包括时间余量,或,包括第四雷达探测装置和第五雷达探测装置之间的同步误差,或,包括时间余量以及第四雷达探测装置和第五雷达探测装置之间的同步误差之和。在参与计算的雷达探测装置有所不同时,同步误差可能会有所不同,时间余量可以不同,或者也可以相同。
例如,第一阈值可以根据第三公式确定,第三公式可以是

 第二阈值可以根据第七公式确定,第七公式可以是

 综合可得:


其中,Δ表示第一信息。例如Δ=Δ
s+δ,或者Δ=Δ
s,或者Δ=δ。Δ
s表示两个雷达探测装置之间的同步误差,如果以第四雷达探测装置和第五雷达探测装置参与计算,则Δ
s表示第四雷达探测装置和第五雷达探测装置之间的同步误差。δ表示时间余量。
其中,确定第一阈值的公式和确定第二阈值的公式可以合并为一个公式,例如公式2.3,那么可以一并确定第一阈值和第二阈值;或者,确定第一阈值的公式和确定第二阈值的公 式也可以单独存在,可以分别确定第一阈值和第二阈值。
以第四雷达探测装置和第五雷达探测装置均为LRR为例。例如,第四LRR的扫频带宽为250MHz,扫频周期为Tc为27.8us,最大探测距离250m,对应的最大中频频率为15MHz。第五LRR发送的雷达信号的斜率(对于一个雷达探测装置来说,发射信号的斜率、反射信号的斜率和发射信号经历传播时延后的信号的斜率都相同)为第四LRR发送的雷达信号的斜率的1.2倍,第五LRR的最大探测距离也为250m,第四LRR发送的雷达信号的最大传播时延为2μs,第五LRR发送的雷达信号的最大传播时延也为2μs(例如第四LRR的雷达信号经过600米的传播后,到达第五LRR接收机处的信号功率为-115dBm,等于第五LRR的接收机灵敏度,故第四LRR的最大传播时延是2μs)。根据最大探测距离为250m可计算出

第四LRR和第五LRR之间的同步误差Δ
s一般参考全球定位系统(global positioning system,GPS)的定时误差,如2μs。若第一信息包括第四LRR和第五LRR之间的同步误差,且不包括时间余量,带入公式2.3可以得到8.7μs≤Δ
t≤21.8μs。δ可以是预先定义或者预先配置的常量,代表LRR本身器件的非理想因素造成的时间抖动,例如以δ=1μs为例。如果第一信息包括时间余量以及第四LRR和第五LRR之间的同步误差,则带入公式2.3可以得到,9.7μs≤Δ
t≤20.8μs。只要使得L个时域范围中的任意两个时延范围的时域起始位置的差值的绝对值大于或等于9.7μs且小于或等于20.8μs,都可以使得在L个时域范围内发送雷达信号的任意两个雷达探测装置之间无干扰。例如,可以使得L个时域范围中的任意两个时延范围的时域起始位置的差值的绝对值等于第一阈值,例如等于9.7μs,这样可以使得互不干扰的雷达探测装置的数量达到最多,提高对于时域资源的利用率。例如取L个时域范围中的任意两个时延范围的时域起始位置的差值的绝对值为9.7μs,则在27.8μs的扫频周期下,可以支持的互不干扰的雷达探测装置的数量为
 关于多个LRR所在的时域范围的一种排布示意图,可继续参考图19。
在考虑了第一信息的情况下,也可以考虑一种特殊的情况,即第四雷达探测装置发送的雷达信号的斜率和第五雷达探测装置发送的雷达信号的斜率相同的情况。那么,公式2.3可以变形为:

公式2.4也可以看做是两个公式,例如,
 可以认为是第四公式,用于确定第一阈值,
 可以认为是第八公式,用于确定第二阈值。其中,确定第一阈值的公式和确定第二阈值的公式可以合并为 一个公式,例如公式2.4,那么可以一并确定第一阈值和第二阈值;或者,确定第一阈值的公式和确定第二阈值的公式也可以单独存在,可以分别确定第一阈值和第二阈值。
以第四雷达探测装置和第五雷达探测装置均为LRR、且第四雷达探测装置的参数和第五雷达探测装置的参数相同为例。例如,LRR的扫频带宽为250MHz,扫频周期Tc为27.8μs,最大探测距离为250m,对应的最大的中频频率为15MHz,也就是第四雷达探测装置发送的雷达信号的最大传播时延和第五雷达探测装置发送的雷达信号的最大传播时延均为2μs(例如第四雷达探测装置的雷达信号经过600米的传播后,到达第五雷达探测装置接收机处的信号功率为-115dBm,等于第五探测装置的接收机灵敏度,故第四雷达探测装置的最大传播时延是2μs)。因为第四雷达探测装置的参数和第五雷达探测装置的参数相同,因此如上的参数是对应于第四雷达探测装置的,也是对应于第五雷达探测装置的。根据最大探测距离为250m可计算出

第四雷达探测装置和第五雷达探测装置之间的同步误差Δ
s一般参考GPS的定时误差,如2μs,如果第一信息包括第四雷达探测装置和第五雷达探测装置之间的同步误差,且不包括时间余量,带入公式2.4可以得到4μs≤Δ
t≤23.8μs。δ可以是预先定义或者预先配置的常量,代表雷达探测装置本身器件的非理想因素造成的时间抖动,例如以δ=1μs为例。如果第一信息包括时间余量以及第四雷达探测装置和第五雷达探测装置之间的同步误差,则带入公式2.4可以得到,5μs≤Δ
t≤22.8μs。只要使得L个时域范围中的任意两个时延范围的时域起始位置的差值的绝对值大于或等于5μs且小于或等于22.8μs,都可以使得在L个时域范围内发送雷达信号的任意两个雷达探测装置之间无干扰。例如,可以使得L个时域范围中的任意两个时延范围的时域起始位置的差值的绝对值等于第一阈值,例如等于5μs,这样可以使得互不干扰的雷达探测装置的数量达到最多,提高对于时域资源的利用率。例如取L个时域范围中的任意两个时延范围的时域起始位置的差值的绝对值为5μs,则在27.8μs的扫频周期下,可以支持的互不干扰的雷达探测装置的数量为
 关于多个LRR所在的时域范围的一种排布示意图,可继续参考图19。
在公式2.4的基础上,如果第四雷达探测装置的最大探测距离对应的回波时延等于第五雷达探测装置的最大探测距离对应的回波时延,且第四雷达探测装置发送的雷达信号的最大传播时延等于第五雷达探测装置发送的雷达信号的最大传播时延,例如第四雷达探测装置和第五雷达探测装置是同一类型的雷达探测装置。那么,公式2.4还可以变形为:
max(τ
max,Δ
p)+Δ≤Δ
t≤T
c-max(τ
max,Δ
p)-Δ (公式2.4-1)
其中,公式2.4-1也可以看做是两个公式,例如,max(τ
max,Δ
p)+Δ≤Δ
t可以认为是第二公式,用于确定第一阈值,Δ
t≤T
c-max(τ
max,Δ
p)-Δ可以认为是第六公式,用于确 定第二阈值。
确定第一阈值的公式和确定第二阈值的公式可以合并为一个公式,例如公式2.4-1,那么可以一并确定第一阈值和第二阈值;或者,确定第一阈值的公式和确定第二阈值的公式也可以单独存在,可以分别确定第一阈值和第二阈值。
以第四雷达探测装置和第五雷达探测装置均为车载雷达为例。例如,第四雷达探测装置的扫频带宽为250MHz,扫频周期为Tc为27.8μs,最大探测距离250m,对应的最大中频频率为15MHz,多雷达间信号的最大传播时延为2μs(例如第四雷达探测装置发射的雷达信号经过600米的传播后,到达第五雷达探测装置接收机处的信号功率为-115dBm,等于第五雷达探测装置的接收机灵敏度,故第四雷达探测装置的最大传播时延是2μs)。根据最大探测距离为250m可计算出

第四雷达探测装置和第五雷达探测装置之间的同步误差Δ
s一般参考GPS的定时误差,如2μs,如果第一信息包括第四雷达探测装置和第五雷达探测装置之间的同步误差,且不包括时间余量,带入公式2.4-1可以得到4μs≤Δ
t≤23.8μs。δ可以是预先定义或者预先配置的常量,代表雷达探测装置本身器件的非理想因素造成的时间抖动,例如以δ=1μs为例。如果第一信息包括时间余量以及第四雷达探测装置和第五雷达探测装置之间的同步误差,则带入公式2.4-1可以得到,5μs≤Δ
t≤22.8μs。只要使得L个时域范围中的任意两个时延范围的时域起始位置的差值的绝对值大于或等于5μs且小于或等于22.8μs,都可以使得在L个时域范围内发送雷达信号的任意两个雷达探测装置之间无干扰。例如,可以使得L个时域范围中的任意两个时延范围的时域起始位置的差值的绝对值等于第一阈值,例如等于5μs,这样可以使得互不干扰的雷达探测装置的数量达到最多,提高对于时域资源的利用率。例如取L个时域范围中的任意两个时延范围的时域起始位置的差值的绝对值为5μs,则在27.8μs的扫频周期下,可以支持的互不干扰的雷达探测装置的数量为
 关于多个LRR所在的时域范围的一种排布示意图,可继续参考图19。
如上介绍的是雷达探测装置是可移动的雷达探测装置的情况,下面再介绍雷达探测装置不可移动的情况。
二、雷达探测装置的位置是固定的。例如雷达探测装置固定在RSU上,或者固定在基站上,或者固定在其他的设备上。或者雷达探测装置也可以独立部署,但位置是固定的。
在这种情况下,可以根据至少一个传播时延和至少一个回波时延来确定第一阈值(或者说,确定第一子阈值),也可以根据至少一个传播时延和至少一个回波时延来确定第二阈值(或者说,确定第二子阈值)。
以第四雷达探测装置和第五雷达探测装置参与计算为例,就是根据第四雷达探测装置的最大探测距离对应的回波时延、第五雷达探测装置的最大探测距离对应的回波时延、第四雷达探测装置发送的雷达信号的传播时延、以及第五雷达探测装置发送的雷达信号的传 播时延来确定第一阈值。同理,以第六雷达探测装置和第七雷达探测装置参与计算为例,就是根据第六雷达探测装置的最大探测距离对应的回波时延、第七雷达探测装置的最大探测距离对应的回波时延、第六雷达探测装置发送的雷达信号的传播时延、以第七雷达探测装置发送的雷达信号的传播时延确定第二阈值。
其中,第四雷达探测装置的最大探测距离对应的回波时延和第五雷达探测装置的最大探测距离对应的回波时延,可以相同也可以不同;第四雷达探测装置发送的雷达信号的传播时延和第五雷达探测装置发送的雷达信号的传播时延,可以相同也可以不同。另外,因为雷达探测装置的位置都是固定的,因此,所述的第四雷达探测装置发送的雷达信号的传播时延,是指第四雷达探测装置发送的雷达信号到达第五雷达探测装置的传播时延,所述的第五雷达探测装置发送的雷达信号的传播时延,是指第五雷达探测装置发送的雷达信号到达第四雷达探测装置的传播时延。第六雷达探测装置的最大探测距离对应的回波时延和第七雷达探测装置的最大探测距离对应的回波时延,可以相同也可以不同;第六雷达探测装置发送的雷达信号的传播时延和第七雷达探测装置发送的雷达信号的传播时延,可以相同也可以不同。另外,因为雷达探测装置的位置都是固定的,因此,所述的第六雷达探测装置发送的雷达信号的传播时延,是指第六雷达探测装置发送的雷达信号到达第七雷达探测装置的传播时延,所述的第七雷达探测装置发送的雷达信号的传播时延,是指第七雷达探测装置发送的雷达信号到达第六雷达探测装置的传播时延。
以第四雷达探测装置在时间上早于第五雷达探测装置发送雷达信号为例,本申请实施例在设置L个时域范围中的任意两个时域范围的时域起始位置的差值的绝对值时,同样需要考虑在第一点中所述的第(1)条、第(2)条和第(3)条。
因此,综合如上几条可以得出:

其中,
 表示第四雷达探测装置发送的雷达信号的传播时延,
 表示第五雷达探测装置发送的雷达信号的传播时延。对于公式2.5所涉及的其余的参数的含义,可参考前文的相关介绍。
其中,公式2.5也可以看做是两个公式,例如,

 可以认为是第一公式,用于确定第一阈值,
 可以认为是第五公式,用于确定第二阈值。综合第一条可知,第一公式可以是

 或
 第五公式可以是
 或


确定第一阈值的公式和确定第二阈值的公式可以合并为一个公式,例如公式2.5,那么可以一并确定第一阈值和第二阈值;或者,确定第一阈值的公式和确定第二阈值的公式也可以单独存在,可以分别确定第一阈值和第二阈值。
可参考图22,为按照如上方法所确定的第四雷达探测装置的时域范围和第五雷达探测装置的时域范围的示意图。图22中,实线都表示第四雷达探测装置的信号,虚线都表示第五雷达探测装置的信号(竖直的三条虚线除外),B表示第四雷达探测装置的扫频带宽。根据要求可知,第五雷达探测装置发出雷达信号的时刻至少需要晚于第四雷达探测装置的最大探测距离对应的回波时延(图22中,从左往右的第一条实线表示第四雷达探测装置在一个周期的发射信号,从左往右的第二条实线表示该发射信号的反射信号,也就是回波信号,从左往右的第三条实线表示该发射信号经历传播时延
 后的信号),以及要晚于第四雷达探测装置发送的雷达信号的传播时延,这样第四雷达探测装置的发射信号才不会被第五雷达探测装置当做接收信号所接收。因此有,


另外还需要保证,第五雷达探测装置的发射信号在带宽B的范围内不会落到第四雷达探测装置的目标回波观察范围内,也就是说,使得第五雷达探测装置的发射信号在带宽B的范围内不会与第四雷达探测装置的目标回波观察范围相交,当然也要保证第四雷达探测装置的发射信号在带宽B的范围内不会落到第五雷达探测装置的目标回波观察范围内。因此有,

 而且,a
2需要满足以下的约束,如上的公式才能对第五雷达探测装置的扫频周期没有限制:

综合如上的三个公式,可以得到公式2.5。在图22中可以看到,两个雷达探测装置的发射信号彼此都不会对方的目标回波观察范围内,不会给对方造成干扰。另外,图22是以第四雷达探测装置的信号作为基准,要使得第五雷达探测装置的雷达信号满足相应的需求以使得两个雷达探测装置之间不会相互干扰,因此在将公式2.5应用于图22时,T
c可以是第四雷达探测装置的发送周期。
以第四雷达探测装置和第五雷达探测装置均为设置在RSU上的雷达为例,可分别称为RSU雷达1和RSU雷达2。例如,RSU雷达1的扫频带宽为250MHz,扫频周期T
c为27.8μs,最大探测距离为250m,对应的最大中频频率为15MHz。RSU雷达2发送的雷达信号的斜率为RSU雷达1发送的雷达信号的斜率的1.2倍,RSU雷达2的最大探测距离为200m,扫频带宽为250MHz,扫频周期T
c为27.8μs,对应的最大中频频率为15MHz。假设RSU 雷达1和RSU雷达2相距300m,则可得出
 根据第四雷达探测装置的最大探测距离为250m可计算出
 以及,根据第五雷达探测装置的最大探测距离为200m可计算出

带入公式2.5可得,

 即为5.7μs≤Δ
t≤26.7μs。例如取L个时域范围中的任意两个时域范围的时域起始位置的差值的绝对值为5.7μs,则在27.8μs的扫频时长下,可以支持的互不干扰的雷达探测装置的数量为

关于多个雷达探测装置所在的时域范围的一种排布示意图,可继续参考图19。
还有一种较为特殊的情况,就是第四雷达探测装置发送的雷达信号的斜率和第五雷达探测装置发送的雷达信号的斜率相同,那么,公式2.5可以变形为:

其中,公式2.6也可以看做是两个公式,例如,

 可以认为是第二公式,用于确定第一阈值,

 可以认为是第六公式,用于确定第二阈值。综合第一条可知,第二公式可以是
 或
 第六公式可以是
 或


确定第一阈值的公式和确定第二阈值的公式可以合并为一个公式,例如公式2.6,那么可以一并确定第一阈值和第二阈值;或者,确定第一阈值的公式和确定第二阈值的公式也可以单独存在,可以分别确定第一阈值和第二阈值。
可参考图23,为按照如上方法所确定的第四雷达探测装置的时域范围和第五雷达探测装置的时域范围的示意图。图23中,实线都表示第四雷达探测装置的信号,虚线都表示第五雷达探测装置的信号(竖直的三条虚线除外),B表示第四雷达探测装置的扫频带宽,从左往右的第一条实线表示第四雷达探测装置在一个周期的发射信号,从左往右的第二条实线表示该发射信号经历传播时延
 后的信号,从左往右的第三条实线表示该发射信号的反射信号,也就是回波信号。要求第四雷达探测装置的发射信号以及该发射信号经历传播时延
 后的信号不落在第五雷达探测装置的目标回波观察范围内,因此有,
 而因为第四雷达探测装置发送的雷达信号的斜率和第五雷达探测装置发送的雷达信号的 斜率相同,因此不用考虑两个雷达探测装置的波形会相交的情况,那么
 就是公式2.6。在图23中可以看到,两个雷达探测装置的发射信号彼此都不会落在对方的目标回波观察范围内,不会给对方造成干扰。
另外,图23是以第四雷达探测装置的雷达信号作为基准,要使得第五雷达探测装置的雷达信号满足相应的需求以使得两个雷达探测装置之间不会相互干扰,因此在将公式2.6应用于图23时,T
c可以是第四雷达探测装置的发送周期。
以第四雷达探测装置和第五雷达探测装置均为设置在RSU上的雷达为例,可分别称为RSU雷达1和RSU雷达2,RSU雷达1发送的雷达信号的斜率和RSU雷达2发送的雷达信号的斜率相同。例如,RSU雷达1的扫频带宽为250MHz,扫频周期T
c为27.8μs,最大探测距离为250m,对应的最大中频频率为15MHz。RSU雷达2的最大探测距离为250m,扫频带宽为250MHz,扫频周期T
c为27.8μs,对应的最大中频频率为15MHz。假设RSU雷达1和RSU雷达2相距300m,则可得出
 根据最大探测距离为250m可计算出

带入公式2.6可得,max(1.67,1)≤Δ
t≤27.8-max(1.67,1),即为1μs≤Δ
t≤26.8μs。例如取L个时域范围中的任意两个时域范围的时域起始位置的差值的绝对值为1μs,则在27.8μs的扫频时长下,可以支持的互不干扰的LRR的数量为

关于多个LRR所在的时域范围的一种排布示意图,可继续参考图19。
再例如,在公式2.6的基础上,如果第四雷达探测装置的最大探测距离对应的回波时延等于第五雷达探测装置的最大探测距离对应的回波时延,且第四雷达探测装置发送的雷达信号的传播时延等于第五雷达探测装置发送的雷达信号的传播时延,那么,公式2.6可以变形为:
max(Δ
p,τ
max-Δ
p)≤Δ
t≤T
c-max(Δ
p,τ
max-Δ
p) (公式2.6-1)
其中,公式2.6-1也可以看做是两个公式,例如,max(Δ
p,τ
max-Δ
p)≤Δ
t可以认为是第二公式,用于确定第一阈值,Δ
t≤T
c-max(Δ
p,τ
max-Δ
p)可以认为是第六公式,用于确定第二阈值。综合第一条可知,第二公式可以是
 或
 或max(Δ
p,τ
max-Δ
p)≤Δ
t,第六公式可以是
 或

 或

确定第一阈值的公式和确定第二阈值的公式可以合并为一个公式,例如公式2.6-1,那么可以一并确定第一阈值和第二阈值;或者,确定第一阈值的公式和确定第二阈值的公式 也可以单独存在,可以分别确定第一阈值和第二阈值。
以第四雷达探测装置和第五雷达探测装置均为设置在RSU上的雷达为例,可分别称为RSU雷达1和RSU雷达2。例如,RSU雷达1的扫频带宽为250MHz,扫频周期T
c为27.8μs,最大探测距离为250m,对应的最大中频频率为15MHz。假设RSU雷达1和RSU雷达2相距300m,则可得出Δ
p=1μs。根据最大探测距离为250m可计算出τ
max=250×2/光速≈1.67μs。
带入公式2.6-1可得,max(1.67,1)≤Δ
t≤27.8-max(1.67,1),即为1μs≤Δ
t≤26.8μs。例如取L个时域范围中的任意两个时域范围的时域起始位置的差值的绝对值为1μs,则在27.8μs的扫频时长下,可以支持的互不干扰的LRR的数量为

作为一种可选的实施方式,公式2.6和公式2.6-1可以认为是适用于第四雷达探测装置和第五雷达探测装置之间的距离小于
 和
 中的较大值所对应的光速传播距离的情况。也就是说,在传播时间为
 和
 中的较大值,且传播速度为光速时,可以计算得到一个距离,该距离就是
 和
 中的较大值所对应的光速传播距离。如果第四雷达探测装置发送的雷达信号的斜率和第五雷达探测装置发送的雷达信号的斜率相同,且第四雷达探测装置和第五雷达探测装置之间的距离小于该距离,就可以使用公式2.6或公式2.6-1。而如果第四雷达探测装置和第五雷达探测装置之间的距离大于或等于该距离,关于确定Δ
t,还可以有其他的方式。
例如,如果第四雷达探测装置和第五雷达探测装置之间的距离大于或等于
 和
 中的较大值所对应的光速传播距离,则Δ
t可以取T
c的整数倍,也就是说,Δ
t=MT
c,M为正整数。例如简单起见,M可以取0,则第四雷达探测装置和第五雷达探测装置同时发送信号即可。
可参考图24,为按照如上方法所确定的第四雷达探测装置的时域范围和第五雷达探测装置的时域范围的示意图。图24中,从左往右的第一条实线表示第四雷达探测装置在一个周期的发射信号,也表示第五雷达探测装置在一个周期的发射信号,从左往右的第二条实线表示第四雷达探测装置的发射信号的反射信号,也就是回波信号,从左往右的第一条虚线表示第五雷达探测装置的发射信号的反射信号,也就是回波信号,从左往右的第三条实线表示第四雷达探测装置的发射信号经历传播时延
 后的信号,从左往右的第二条虚线表示第五雷达探测装置的发射信号经历传播时延
 后的信号。可以看到,两个雷达探测装置的发射信号彼此都不会落在对方的目标回波观察范围内,不会给对方造成干扰。
如上的公式2.5、公式2.6或公式2.6-1并未考虑第一信息,如果考虑第一信息,那么第一阈值的确定方法会有所不同。例如,可以根据至少一个回波时延、至少一个传播时延和第一信息来确定第一阈值。同理,可以根据至少一个回波时延、至少一个传播时延和第一信息来确定第二阈值。
如果以第四雷达探测装置和第五雷达探测装置参与计算为例,则可以根据第一雷达探 测装置的最大探测距离对应的回波时延、第二雷达探测装置的最大探测距离对应的回波时延、第一雷达探测装置所发送的雷达信号的传播时延、第二雷达探测装置所发送的雷达信号的传播时延、以及第一信息确定第一阈值。同理,如果以第四雷达探测装置和第五雷达探测装置参与计算为例,则可以根据第一雷达探测装置的最大探测距离对应的回波时延、第二雷达探测装置的最大探测距离对应的回波时延、第一雷达探测装置所发送的雷达信号的传播时延、第二雷达探测装置所发送的雷达信号的传播时延、以及第一信息确定第二阈值。
例如,第一阈值可以根据第三公式确定,第三公式可以是

 第二阈值可以根据第七公式确定,第七公式可以是
 综合可得:

其中,确定第一阈值的公式和确定第二阈值的公式可以合并为一个公式,例如公式2.7,那么可以一并确定第一阈值和第二阈值;或者,确定第一阈值的公式和确定第二阈值的公式也可以单独存在,可以分别确定第一阈值和第二阈值。
另外综合第一条可知,第三公式为

 或
 第七公式为

 或


以第四雷达探测装置和第五雷达探测装置均为设置在RSU上的雷达为例,可分别称为RSU雷达1和RSU雷达2,例如RSU雷达2发送的雷达信号的斜率是RSU雷达1发送的雷达信号的斜率的1.2倍。例如,RSU雷达1的扫频带宽为250MHz,扫频周期T
c为27.8μs,最大探测距离为250m,对应的最大中频频率为15MHz。RSU雷达2发送的雷达信号的斜率是RSU雷达1发送的雷达信号的斜率的1.2倍,RSU雷达2的最大探测距离为200m,扫频带宽为250MHz,扫频周期T
c为27.8μs,对应的最大中频频率为15MHz。假设RSU雷达1和RSU雷达2相距300m,则可得出
 根据RSU雷达1的最大探测距离为250m可计算出
 以及,根据RSU雷达2的最大探测距离为200m可计算出

带入公式2.5可得,

 即为5.7μs≤Δ
t≤26.7μs。RSU雷达1和RSU雷达1之间的同步误差Δ
s可以参考GPS的定时误差,如2μs,如果第一信息包括RSU雷达1和RSU雷达2之间的同步误差,且不包括时间余量,带入公式2.7可以得到7.7μs≤Δ
t≤24.7μs。δ可以是预先定义或者预先配置的常量,代表RSU雷达本身器件的非理想因素造成的时间抖动,例如以δ=1μs为例,如果第一信息包括时间余量以及RSU雷达1和RSU雷达2之间的同步误差,则带入公式2.7可以得到,8.7μs≤Δ
t≤23.7μs。只要使得L个时域范围中的任意两个时域范围的时域起始位置的差值的绝对值大于或等于8.7μs且小于或等于23.7μs,都可以在L个时域范围内发送雷达信号的任意两个雷达探测装置之间无干扰。例如,可以使得L个时域范围中的任意两个时域范围的时域起始位置的差值的绝对值等于第一阈值,例如等于8.7μs,这样可以使得互不干扰的雷达探测装置的数量达到最多,提高对于时域资源的利用率。例如取L个时域范围中的任意两个时域范围的时域起始位置的差值的绝对值为8.7μs,则在27.8μs的扫频周期下,可以支持的互不干扰的雷达探测装置的数量为
 关于多个LRR所在的时域范围的一种排布示意图,可继续参考图19。
在考虑了第一信息的情况下,也可以考虑一种特殊的情况,即第四雷达探测装置发送的雷达信号的斜率和第五雷达探测装置发送的雷达信号的斜率相同的情况。那么,公式2.7可以变形为:

公式2.8也可以看做是两个公式,例如,
 可以认为是第四公式,用于确定第一阈值,

 可以认为是第八公式,用于确定第二阈值。其中,确定第一阈值的公式和确定第二阈值的公式可以合并为一个公式,例如公式2.8,那么可以一并确定第一阈值和第二阈值;或者,确定第一阈值的公式和确定第二阈值的公式也可以单独存在,可以分别确定第一阈值和第二阈值。
另外,综合第一条可知,第四公式可以是
 或
 第八公式可以是
 或


以第四雷达探测装置和第五雷达探测装置均为设置在RSU上的雷达为例,可分别称为RSU雷达1和RSU雷达2,例如RSU雷达1发送的雷达信号的斜率与RSU雷达2发送的 雷达信号的斜率相等。例如,RSU雷达1的扫频带宽为250MHz,扫频周期T
c为27.8μs,最大探测距离为250m,对应的最大中频频率为15MHz。RSU雷达2的最大探测距离为250m,扫频带宽为250MHz,扫频周期T
c为27.8μs,对应的最大中频频率为15MHz。假设RSU雷达1和RSU雷达2相距300m,则可得出
 根据最大探测距离为250m可计算出

带入公式2.8可得,max(1,1.67-1)≤Δ
t≤27.8-max(1,1.67-1),即为1μs≤Δ
t≤26.8μs。RSU雷达1和RSU雷达2之间的同步误差Δ
s可以参考GPS的定时误差,如2μs,如果第一信息包括RSU雷达1和RSU雷达2之间的同步误差,且不包括时间余量,带入公式2.8可以得到3μs≤Δ
t≤24.8μs。δ可以是预先定义或者预先配置的常量,代表RSU雷达本身器件的非理想因素造成的时间抖动,例如以δ=1μs为例,如果第一信息包括时间余量以及RSU雷达1和RSU雷达2之间的同步误差,则带入公式2.8可以得到,4μs≤Δ
t≤23.8μs。只要使得L个时域范围中的任意两个时域范围的时域起始位置的差值的绝对值大于或等于4μs且小于或等于23.8μs,都可以使得在L个时域范围内发送雷达信号的任意两个雷达探测装置之间无干扰。例如,可以使得L个时域范围中的任意两个时域范围的时域起始位置的差值的绝对值等于第一阈值,例如等于4μs,这样可以使得互不干扰的雷达探测装置的数量达到最多,提高对于时域资源的利用率。例如取L个时域范围中的任意两个时域范围的时域起始位置的差值的绝对值为4μs,则在27.8μs的扫频周期下,可以支持的互不干扰的雷达探测装置的数量为
 关于多个LRR所在的时域范围的一种排布示意图,可继续参考图19。
同理,如果第四雷达探测装置发送的雷达信号的斜率和第五雷达探测装置发送的雷达信号的斜率相同,且考虑同步误差和时间余量,以及第四雷达探测装置和第五雷达探测装置之间的距离小于该距离,则可以使用公式2.8。而如果第四雷达探测装置和第五雷达探测装置之间的距离大于或等于该距离,关于确定Δ
t,还可以有其他的方式。
例如,如果第四雷达探测装置和第五雷达探测装置之间的距离大于或等于
 和
 中的较大值所对应的光速传播距离,则Δ
t可以取T
c的整数倍,也就是说,Δ
t=MT
c,M为正整数。例如简单起见,M可以取0,则第四雷达探测装置和第五雷达探测装置同时发送信号即可。
在公式2.8的基础上,如果第四雷达探测装置的最大探测距离对应的回波时延等于第五雷达探测装置的最大探测距离对应的回波时延,且第四雷达探测装置发送的雷达信号的最大传播时延等于第五雷达探测装置发送的雷达信号的最大传播时延,例如第四雷达探测装置和第五雷达探测装置是同一类型的雷达探测装置。那么,公式2.8可以变形为:

公式2.8-1也可以看做是两个公式,例如,
 可以认为是第四公式,用于确定第一阈值,
 可以认为是第八公式,用于确定第二阈值。其中,确定第一阈值的公式和确定第二阈值的公式可以合并为一个公式,例如公式2.8-1,那么可以一并确定第一阈值和第二阈值;或者,确定第一阈值的公式和确定第二阈值的公式也可以单独存在,可以分别确定第一阈值和第二阈值。
另外,综合第一条可知,第四公式可以是
 或
 或
 第八公式可以是
 或

 或

以第四雷达探测装置和第五雷达探测装置均为设置在RSU上的雷达为例,可分别称为RSU雷达1和RSU雷达2。例如,RSU雷达1的扫频带宽为250MHz,扫频周期T
c为27.8μs,最大探测距离为250m,对应的最大中频频率为15MHz。假设RSU雷达1和RSU雷达2相距300m,则可得出Δ
p=1μs。根据最大探测距离为250m可计算出τ
max=250×2/光速≈1.67μs。
带入公式2.8-1可得,max(1,1.67-1)≤Δ
t≤27.8-max(1,1.67-1),即为1μs≤Δ
t≤26.8μs。RSU雷达1和RSU雷达2之间的同步误差Δ
s可以参考GPS的定时误差,如2μs,如果第一信息包括RSU雷达1和RSU雷达2之间的同步误差,且不包括时间余量,带入公式2.8-1可以得到3μs≤Δ
t≤24.8μs。δ可以是预先定义或者预先配置的常量,代表RSU雷达本身器件的非理想因素造成的时间抖动,例如以δ=1μs为例,如果第一信息包括时间余量以及RSU雷达1和RSU雷达2之间的同步误差,则带入公式2.8-1可以得到,4μs≤Δ
t≤23.8μs。只要使得L个时域范围中的任意两个时域范围的时域起始位置的差值的绝对值大于或等于4μs且小于或等于23.8μs,都可以使得在L个时域范围内发送雷达信号的任意两个雷达探测装置之间无干扰。例如,可以使得L个时域范围中的任意两个时域范围的时域起始位置的差值的绝对值等于第一阈值,例如等于4μs,这样可以使得互不干扰的雷达探测装置的数量达到最多,提高对于时域资源的利用率。例如取L个时域范围中的任意两个时域范围的时域起始位置的差值的绝对值为4μs,则在27.8μs的扫频周期下,可以支持的互不干扰的雷达探测装置的数量为
 关于多个LRR所在的时域范围的一种排布示意图,可继续参考图19。
在前文介绍了,如果有多个雷达探测装置(或者多类雷达探测装置),则可以求得多 个第一子阈值,再取多个第一子阈值中的最大值作为第一阈值。同理,如果有多个雷达探测装置(或者多类雷达探测装置),则可以求得多个第二子阈值,再取多个第二子阈值中的最大值作为第二阈值。以下举例介绍。例如,最终的第一阈值采用的是根据第四雷达探测装置和第五雷达探测装置计算得到的第一子阈值,第二阈值采用的是根据第六雷达探测装置和第七雷达探测装置计算得到的第二子阈值。也就是说,可以根据第四雷达探测装置的最大探测距离对应的回波时延、第五雷达探测装置的最大探测距离对应的回波时延、第四雷达探测装置发送的雷达信号的最大传播时延(或者说,第四雷达探测装置的发射信号的最大传播时延)、以及第五雷达探测装置发送的雷达信号的最大传播时延(或者说,第五雷达探测装置的发射信号的最大传播时延),确定一个第一子阈值,该第一子阈值就是多个第一子阈值中的最大值,也就是最终的第一阈值。可以根据第六雷达探测装置的最大探测距离对应的回波时延、第七雷达探测装置的最大探测距离对应的回波时延、第六雷达探测装置发送的雷达信号的最大传播时延、以及第七雷达探测装置发送的雷达信号的最大传播时延,确定一个第二子阈值,该第二子阈值就是多个第二子阈值中的最大值,也就是最终的第二阈值。
另外,在如上的介绍过程中,是以根据第四雷达探测装置和第五雷达探测装置计算得到第二子阈值为例,如果根据第六雷达探测装置和第七雷达探测装置来计算得到第二子阈值(最终会作为第二阈值),那么计算公式可以与如上的公式相同,为了简化,在根据雷达探测装置和第七雷达探测装置来计算得到第二子阈值时,也可以采用上述的用于计算第二子阈值的公式中的各个字母代表对应的参数,相当于,本申请实施例可能用相同的字母代表了不同的参数。例如公式2.1~公式2.8中的任一个公式,只需代入相应的雷达探测装置的参数,就可以根据相应的雷达探测装置进行计算。在如上的介绍过程中,在公式2.1~公式2.8中代入的均是第四雷达探测装置和第五雷达探测装置的参数,而还可以并不代入第四雷达探测装置和第五雷达探测装置的参数,而是代入第六雷达探测装置和第七雷达探测装置的参数,这样就是根据第六雷达探测装置和第七雷达探测装置计算第一子阈值或第二子阈值。
第四雷达探测装置和第六雷达探测装置可以是同一个探测装置,或者也可以是不同的探测装置;第五雷达探测装置和第七雷达探测装置可以是同一个探测装置,或者也可以是不同的探测装置。
例如,有雷达探测装置1、雷达探测装置2和雷达探测装置3,雷达探测装置1与雷达探测装置2相距300m,雷达探测装置1与雷达探测装置3相距400m,雷达探测装置2与雷达探测装置3相距500m,且,雷达探测装置1发送的雷达信号的斜率、雷达探测装置2发送的雷达信号的斜率以及雷达探测装置3发送的雷达信号的斜率相同。例如不考虑第一信息,根据公式2.5计算得到,雷达探测装置1的时域范围与雷达探测装置2的时域范围的时域起始位置的差值的绝对值的范围为1μs≤Δ
t≤26.8μs,雷达探测装置1的时域范围与雷达探测装置3的时域范围的时域起始位置的差值的绝对值的范围为1.3μs≤Δ
t≤26.5μs,雷达探测装置2的时域范围与雷达探测装置3的时域范围的时域起始位置的差值的绝对值的范围为1.67μs≤Δ
t≤26.1μs,则,取这三个范围的交集(也就是相当于, 取多个第一子阈值中的最大值为第一阈值,取多个第二子阈值中的最小值为第二阈值),可得L个时域范围中的任意两个时域范围的时域起始位置的差值的绝对值的范围为1.67μs≤Δ
t≤26.1μs。
在本申请实施例中,可以由一个雷达探测装置计算Δ
t,从而确定L个时域范围,再将L个时域范围的信息发送给其他的雷达探测装置。这样,雷达探测装置从L个时域范围内选择相应的时域范围来发送雷达信号即可。或者,L个时域范围也可以是通过协议规定的,例如协议规定了L个时域范围和Δ
t,这样,雷达探测装置从L个时域范围内选择相应的时域范围来发送雷达信号即可。或者,L个时域范围也可以预配置在雷达探测装置中,例如L个时域范围的信息和Δ
t都预配置在雷达探测装置中,这样,雷达探测装置从L个时域范围内选择相应的时域范围来发送雷达信号即可。
另外在实际应用中,可以通过本申请实施例提供的方法来计算第一阈值和第二阈值,从而根据第一阈值和第二阈值确定Δ
t;或者,也可以只是通过本申请实施例提供的方法来计算第一阈值,而第二阈值可以通过其他方式来计算,再根据第一阈值和第二阈值确定Δ
t,对于第二阈值的计算方法不做限制;或者,也可以只是通过本申请实施例提供的方法来计算第二阈值,而第一阈值可以通过其他方式来计算,再根据第一阈值和第二阈值确定Δ
t,对于第一阈值的计算方法不做限制。
S1702、第一雷达探测装置在所述第一时域范围内发送第一雷达信号。
在选择第一时域范围后,第一雷达探测装置就可以在第一时域范围内发送第一雷达信号,第一雷达信号到达目标物体后可以反射回来,从而第一雷达装置接收反射信号,第一雷达装置将反射信号和本振信号进行混频,得到中频信号,从而根据该中频信号就可以确定目标物体的位置、速度或角度等信息中的一个或多个。
如果还有其他的雷达探测装置也需要发送雷达信号,例如还有第二雷达探测装置,那么第二雷达探测装置可以从L个时域范围内选择第二时域范围来发送第二雷达信号。
也就是说,不同的雷达探测装置可以选择不同的时域范围来发送雷达信号。第一时域范围和第二时域范围可以有交集,也可以没有交集,如果第一时域范围和第二时域范围有交集,那么第一时域范围和第二时域范围的时域起始位置的差值的绝对值可以是在S1701中所计算的Δ
t。从而通过本申请实施例提供的方法,可以保证雷达探测装置的相互干扰区域消失,避免出现虚警或者干扰平台的问题。另外,本申请实施例还可以令Δ
t取所计算的范围中的最小值,也就是令Δ
t等于第一阈值,则在相同的可用时域资源下,可以使得可支持的互不干扰的雷达探测装置的数量最多,极大地增加了对时域资源的利用率。
上述主要从第一雷达探测装置的角度,或者说是从第一雷达探测装置与雷达探测装置之间,或者与目标物体之间交互的角度对本申请实施例提供的方案进行了介绍。上述方案中所涉及的公式只是一种具体的表达方式,为解决相同的技术问题并达到相同或类似的技术效果而对上述公式进行的可能的变型或者改写,都在本申请实施例的保护范围之内。可以理解的是,各个装置,例如第一雷达探测装置为了实现上述功能,其包含了执行各个功能相应的硬件结构和/或软件模块。本领域技术人员应该很容易意识到,结合本文中所公开的实施例描述的各示例的单元及算法步骤,本申请实施例能够以硬件或硬件和计算机软件的结合形式来实现。某个功能究竟以硬件还是计算机软件驱动硬件的方式来执行,取决于技术方案的特定应用和设计约束条件。专业技术人员可以对每个特定的应用来使用不同方 法来实现所描述的功能,但是这种实现不应认为超出本申请实施例的范围。
本申请实施例可以对第一雷达探测装置进行功能模块的划分,例如,可对应各个功能划分各个功能模块,也可将两个或两个以上的功能集成在一个处理模块中。上述集成的模块既可以采用硬件的形式实现,也可以采用软件功能模块的形式实现。需要说明的是,本申请实施例中对模块的划分是示意性的,仅仅为一种逻辑功能划分,实际实现时可以有另外的划分方式。
例如,以采用集成的方式划分雷达探测装置各个功能模块的情况下,图25示出了本申请上述实施例中所涉及的第一雷达探测装置的一种可能的结构示意图。该第一雷达探测装置25可以包括处理单元2501和收发单元2502。其中,处理单元2501可以用于执行图17A所示的实施例中由第一雷达探测装置所执行的除了收发操作之外的全部操作,例如S1701,和/或用于支持本文所描述的技术的其它过程。收发单元2502可以用于执行图17A所示的实施例中由第一雷达探测装置所执行的全部收发操作,例如S1702,和/或用于支持本文所描述的技术的其它过程。
处理单元2501,用于确定第一时域范围,所述第一时域范围为L个时域范围中的时域范围,所述L为大于1的正整数;
收发单元2502,用于在所述第一时域范围内发送第一雷达信号;其中,所述L个时域范围中的任一个时域范围与其它L-1个时域范围中的至少一个时域范围部分重叠,所述L个时域范围中任两个时域范围的时域起始位置的差值的绝对值大于或等于第一阈值且小于或等于第二阈值;所述第一阈值是根据至少一个回波时延和至少一个传播时延确定的,所述至少一个回波时延包含第一雷达探测装置25的最大探测距离对应的第一回波时延,所述至少一个传播时延包括所述第一雷达信号对应的第一传播时延。
作为一种可选的实施方式,所述至少一个回波时延包含第二回波时延,所述第二回波时延为第二雷达探测装置的最大探测距离对应的回波时延,和/或,所述至少一个传播时延包含第二传播时延,所述第二传播时延为第三雷达探测装置对应的第三雷达信号对应的传播时延;其中,所述第二回波时延不等于所述第一回波时延,所述第二传播时延不等于所述第一传播时延。
作为一种可选的实施方式,所述第一阈值为多个第一子阈值中的最大值,所述多个第一子阈值为根据所述至少一个回波时延和所述至少一个传播时延确定的。
作为一种可选的实施方式,所述第一阈值满足如下公式:


其中,
 为第四雷达探测装置的最大探测距离所对应的回波时延,
 为第五雷达探测装置的最大探测距离所对应的回波时延,
 为第四雷达信号对应的传播时延,
 为第五雷达信号对应的传播时延,a
1为所述第四雷达信号在单位时间内的频率变化量,a
2为所述第五雷达信号在单位时间内的频率变化量,T
c为所述第四雷达探测装置的扫频时间,所述第四雷达信号对应于所述第四雷达探测装置,所述第五雷达信号对应于所述第五雷达探测装置,Δ为时间余量,或为同步误差,或为时间余量与同步误差之和,所述同步 误差为所述第四雷达探测装置和所述第五雷达探测装置之间的同步误差。
作为一种可选的实施方式,所述第四雷达信号对应的传播时延为所述第四雷达信号对应的最大传播时延,所述第五雷达信号对应的传播时延为所述第五雷达信号对应的最大传播时延。
作为一种可选的实施方式,所述第二阈值是根据所述至少一个回波时延和所述至少一个传播时延确定的。
作为一种可选的实施方式,所述第二阈值为多个第二子阈值中的最小值,所述多个第二子阈值为根据所述至少一个回波时延和所述至少一个传播时延确定的。
作为一种可选的实施方式,所述第二阈值满足如下公式:


其中,
 为第六雷达探测装置的最大探测距离所对应的回波时延,
 为第七雷达探测装置的最大探测距离所对应的回波时延,
 为第六雷达信号对应的传播时延,
 为第七雷达信号对应的传播时延,a
1为所述第六雷达信号在单位时间内的频率变化量,a
2为所述第七雷达信号在单位时间内的频率变化量,T
c为所述第六雷达探测装置的扫频时间,所述第六雷达信号对应于所述第六雷达探测装置,所述第七雷达信号对应于所述第七雷达探测装置,Δ为时间余量,或为同步误差,或为时间余量与同步误差之和,所述同步误差为所述第六雷达探测装置和所述第七雷达探测装置之间的同步误差。
作为一种可选的实施方式,所述第四雷达信号对应的传播时延为所述第四雷达信号对应的最大传播时延,所述第五雷达信号对应的传播时延为所述第五雷达信号对应的最大传播时延。
作为一种可选的实施方式,所述第一阈值满足如下公式:


其中,
 为第四雷达探测装置的最大探测距离所对应的回波时延,
 为第五雷达探测装置的最大探测距离所对应的回波时延,
 为第四雷达信号对应的传播时延,
 为第五雷达信号对应的传播时延,a
1为所述第四雷达信号在单位时间内的频率变化量,a
2为所述第五雷达信号在单位时间内的频率变化量,T
c为所述第四雷达探测装置的扫频时间,所述第四雷达信号对应于所述第四雷达探测装置,所述第五雷达信号对应于所述第五雷达探测装置,Δ为时间余量,或为同步误差,或为时间余量与同步误差之和,所述同步误差为所述第四雷达探测装置和所述第五雷达探测装置之间的同步误差。
作为一种可选的实施方式,所述第二阈值是根据所述至少一个回波时延和所述至少一个传播时延确定的。
作为一种可选的实施方式,所述第二阈值为多个第二子阈值中的最小值,所述多个第二子阈值为根据所述至少一个回波时延和所述至少一个传播时延确定的。
作为一种可选的实施方式,所述第二阈值满足如下公式:


其中,
 为第六雷达探测装置的最大探测距离所对应的回波时延,
 为第七雷达探测装置的最大探测距离所对应的回波时延,
 为第六雷达信号对应的传播时延,
 为第七雷达信号对应的传播时延,a
1为第六雷达信号在单位时间内的频率变化量,a
2为第七雷达信号在单位时间内的频率变化量,T
c为所述第六雷达探测装置的扫频时间,所述第六雷达信号对应于所述第六雷达探测装置,所述第七雷达信号对应于所述第七雷达探测装置,Δ为时间余量,或为同步误差,或为时间余量与同步误差之和,所述同步误差为所述第六雷达探测装置和所述第七雷达探测装置之间的同步误差。
作为一种可选的实施方式,所述第四雷达信号对应的传播时延为所述第四雷达信号从所述第四雷达探测装置到达所述第五雷达探测装置的时延,所述第五雷达信号对应的传播时延为所述第五雷达信号从所述第五雷达探测装置到达所述第四雷达探测装置的时延。
可选的,第一雷达探测装置25还可以包含存储单元2503,用于存储程序指令和/或数据,以供处理单元2501读取。
该可选的设计可以独立实现,也可以与上述任一可选的设计集成实现。
图26为本申请实施例提供的第一雷达探测装置的另一种可能的结构示意图。该第一雷达探测装置26可以包处理器2601、发射器2602以及接收器2603。其功能可分别与图25所展示的处理单元2501和收发单元2502的具体功能相对应,此处不再赘述。可选的,第一雷达探测装置26还可以包含存储器2604,用于存储程序指令和/或数据,以供处理器2601读取。
前述图1提供了一种雷达装置的结构示意图。参考上述内容,提出又一可选的方式。图27提供了第一雷达探测装置再一种可能的结构示意图。图25~图27所提供的第一雷达探测装置可以为实际通信场景中雷达装置的部分或者全部,或者可以是集成在雷达装置中或者位于雷达装置外部的功能模块,例如可以是芯片系统,具体以实现相应的功能为准,不对第一雷达探测装置结构和组成进行具体限定。
该可选的方式中,第一雷达探测装置27包括发射天线2701、接收天线2702以及处理器2703。进一步,所述第一雷达探测装置还包括混频器2704和/或振荡器2705。进一步,第一雷达探测装置27还可以包括低通滤波器和/或定向耦合器等。其中,发射天线2701和接收天线2702用于支持所述探测装置进行无线电通信,发射天线2701支持雷达信号的发射,接收天线2702支持雷达信号的接收和/或反射信号的接收,以最终实现探测功能。处理器2703执行一些可能的确定和/或处理功能。进一步,处理器2703还控制发射天线2701和/或接收天线2702的操作。具体的,需要发射的信号通过处理器2703控制发射天线2701进行发射,通过接收天线2702接收到的信号可以传输给处理器2703进行相应的处理。第一雷达探测装置27所包含的各个部件可用于配合执行图17A所示的实施例所提供的方法。 可选的,第一雷达探测装置还可以包含存储器,用于存储程序指令和/或数据。其中,发射天线2701和接收天线2702可以是独立设置的,也可以集成设置为收发天线,执行相应的收发功能。
图28为本申请实施例提供的一种装置28的结构示意图。图28所示的装置28可以是第一雷达探测装置本身,或者可以是能够完成第一雷达探测装置的功能的芯片或电路,例如该芯片或电路可以设置在第一雷达探测装置中。图28所示的装置28可以包括处理器2801(例如处理单元2501可以通过处理器2801实现,处理器2601和处理器2801例如可以是同一部件)和接口电路2802(例如收发单元2502可以通过接口电路2802实现,发射器2602和接收器2603与接口电路2802例如为同一部件)。该处理器2801可以使得装置28实现图17A所示的实施例所提供的方法中第一雷达探测装置所执行的步骤。可选的,装置28还可以包括存储器2803,存储器2803可用于存储指令。处理器2801通过执行存储器2803所存储的指令,使得装置28实现图17A所示的实施例所提供的方法中第一雷达探测装置所执行的步骤。
进一步的,处理器2801、接口电路2802和存储器2803之间可以通过内部连接通路互相通信,传递控制和/或数据信号。存储器2803用于存储计算机程序,处理器2801可以从存储器2803中调用并运行计算机程序,以控制接口电路2802接收信号或发送信号,完成图17A所示的实施例所提供的方法中第一雷达探测装置执行的步骤。存储器2803可以集成在处理器2801中,也可以与处理器2801分开设置。
可选地,若装置28为设备,接口电路2802可以包括接收器和发送器。其中,接收器和发送器可以为相同的部件,或者为不同的部件。接收器和发送器为相同的部件时,可以将该部件称为收发器。
可选地,若装置28为芯片或电路,则接口电路2802可以包括输入接口和输出接口,输入接口和输出接口可以是相同的接口,或者可以分别是不同的接口。
可选地,若装置28为芯片或电路,装置28也可以不包括存储器2803,处理器2801可以读取该芯片或电路外部的存储器中的指令(程序或代码)以实现图17A所示的实施例所提供的方法中第一雷达探测装置执行的步骤。
可选地,若装置28为芯片或电路,则装置28可以包括电阻、电容或其他相应的功能部件,处理器2801或接口电路2802可以通过相应的功能部件实现。
作为一种实现方式,接口电路2802的功能可以考虑通过收发电路或收发的专用芯片实现。处理器2801可以考虑通过专用处理芯片、处理电路、处理器或通用芯片实现。
作为另一种实现方式,可以考虑使用通用计算机的方式来实现本申请实施例提供的第一雷达探测装置。即,将实现处理器2801、接口电路2802的功能的程序代码存储在存储器2803中,处理器2801通过执行存储器2803存储的程序代码来实现处理器2801、接口电路2802的功能。
其中,以上列举的装置28中各模块或单元的功能和动作仅为示例性说明,装置28中各功能单元可用于执行图17A所示的实施例中第一雷达探测装置所执行的各动作或处理过程。这里为了避免赘述,省略其详细说明。
需要说明的是,第二雷达探测装置、第三雷达探测装置、第四雷达探测装置或第五雷达探测装置等可以具有与第一雷达探测装置相同的结构,即同样适用于图25~图28中所述的结构示意图。
再一种可选的方式,当使用软件实现雷达探测装置时,可以全部或部分地以计算机程序产品的形式实现。所述计算机程序产品包括一个或多个计算机指令。在计算机上加载和执行所述计算机程序指令时,全部或部分地实现本申请实施例所述的流程或功能。所述计算机可以是通用计算机、专用计算机、计算机网络、或者其他可编程装置。所述计算机指令可以存储在计算机可读存储介质中,或者从一个计算机可读存储介质向另一个计算机可读存储介质传输,例如,所述计算机指令可以从一个网站站点、计算机、服务器或数据中心通过有线(例如同轴电缆、光纤、数字用户线(digital subscriber line,DSL))或无线(例如红外、无线、微波等)方式向另一个网站站点、计算机、服务器或数据中心进行传输。所述计算机可读存储介质可以是计算机能够存取的任何可用介质或者是包含一个或多个可用介质集成的服务器、数据中心等数据存储设备。所述可用介质可以是磁性介质,(例如软盘、硬盘、磁带)、光介质(例如DVD)、或者半导体介质(例如固态硬盘(solid state disk,SSD))等。
需要说明的是,用于执行本申请实施例提供的探测方法的上述探测装置中所包含的处理器可以是中央处理器(central processing unit,CPU),通用处理器、数字信号处理器(digital signal processor,DSP)、专用集成电路(application-specific integrated circuit,ASIC),现场可编程门阵列(field programmable gate array,FPGA)或者其他可编程逻辑器件、晶体管逻辑器件,硬件部件或者其任意组合。其可以实现或执行结合本申请公开内容所描述的各种示例性的逻辑方框,模块和电路。所述处理器也可以是实现计算功能的组合,例如包含一个或多个微处理器组合,DSP和微处理器的组合等等。
结合本申请实施例所描述的方法或者算法的步骤可以硬件的方式来实现,也可以是由处理器执行软件指令的方式来实现。软件指令可以由相应的软件模块组成,软件模块可以被存放于随机存取存储器(random access memory,RAM)、闪存、只读存储器(read-only memory,ROM)存储器、可擦除可编程只读存储器(erasable programmable read-only memory,EPROM)、电可擦除可编程只读存储器(electrically erasable programmable read-only memory,EEPROM)、寄存器、硬盘、移动硬盘、只读光盘(compact disc read-only memory,CD-ROM)或者本领域熟知的任何其它形式的存储介质中。一种示例性的存储介质耦合至处理器,从而使处理器能够从该存储介质读取信息,且可向该存储介质写入信息。当然,存储介质也可以是处理器的组成部分。处理器和存储介质可以位于ASIC中。另外,该ASIC可以位于探测装置中。当然,处理器和存储介质也可以作为分立组件存在于探测装置中。
可以理解的是,图25~图28仅仅示出了雷达探测装置的简化设计。在实际应用中,雷达探测装置可以包含任意数量的发射器,接收器,处理器,控制器,存储器以及其他可能存在的元件。
本申请实施例还提供一种通信系统,其包含执行本申请上述实施例所提到的对应于至少一个回波时延和至少一个传播时延的至少一个雷达探测装置。
本申请实施例还提供一种通信系统,其包含执行本申请上述实施例所提到的至少一个雷达探测装置和/或至少一个中央处理器/中央控制器。所述中央处理器/中央控制器用于根据所述至少一个雷达探测装置的输出,控制车辆的行驶和/或其他雷达探测装置的处理。所述中央处理器/中央控制器可以位于车辆中,或者其他可能的位置,以实现所述控制为准。
通过以上的实施方式的描述,所属领域的技术人员可以清楚地了解到,为描述的方便和简洁,仅以上述各功能模块的划分进行举例说明,实际应用中,可以根据需要而将上述 功能分配由不同的功能模块完成,即将装置的内部结构划分成不同的功能模块,以完成以上描述的全部或者部分功能。
在本申请所提供的几个实施例中,应该理解到,所揭露的装置和方法,可以通过其它的方式实现。例如,以上所描述的装置实施例仅仅是示意性的,例如,所述模块或单元的划分,仅仅为一种逻辑功能划分,实际实现时可以有另外的划分方式,例如多个单元或组件可以结合或者可以集成到另一个装置,或一些特征可以忽略,或不执行。另一点,所显示或讨论的相互之间的耦合或直接耦合或通信连接可以是通过一些接口,装置或单元的间接耦合或通信连接,可以是电性,机械或其它的形式。
所述作为分离部件说明的单元可以是或者也可以不是物理上分开的,作为单元显示的部件可以是一个物理单元或多个物理单元,即可以位于一个地方,或者也可以分布到多个不同地方。可以根据实际的需要选择其中的部分或者全部单元来实现本实施例方案的目的。
另外,在本申请各个实施例中的各功能单元可以集成在一个处理单元中,也可以是各个单元单独物理存在,也可以两个或两个以上单元集成在一个单元中。上述集成的单元既可以采用硬件的形式实现,也可以采用软件功能单元的形式实现。
所述集成的单元如果以软件功能单元的形式实现并作为独立的产品销售或使用时,可以存储在一个可读取存储介质中。基于这样的理解,本申请实施例的技术方案本质上或者说对现有技术做出贡献的部分或者该技术方案的全部或部分可以以软件产品的形式体现出来,该软件产品存储在一个存储介质中,包括若干指令用以使得一个设备(可以是单片机,芯片等)或处理器(processor)执行本申请各个实施例所述方法的全部或部分步骤。而前述的存储介质包括:U盘、移动硬盘、ROM、RAM、磁碟或者光盘等各种可以存储程序代码的介质。
以上所述,仅为本申请的具体实施方式,但本申请的保护范围并不局限于此,任何在本申请揭露的技术范围内的变化或替换,都应涵盖在本申请的保护范围之内。因此,本申请的保护范围应以所述权利要求的保护范围为准。
Claims (29)
- 一种雷达信号发送方法,应用于第一雷达探测装置,其特征在于,包括:确定第一时域范围,所述第一时域范围为L个时域范围中的时域范围,所述L为大于1的正整数;在所述第一时域范围内发送第一雷达信号;其中,所述L个时域范围中的任一个时域范围与其它L-1个时域范围中的至少一个时域范围部分重叠,所述L个时域范围中任两个时域范围的时域起始位置的差值的绝对值大于或等于第一阈值且小于或等于第二阈值;所述第一阈值是根据至少一个回波时延和至少一个传播时延确定的,所述至少一个回波时延包含所述第一雷达探测装置的最大探测距离对应的第一回波时延,所述至少一个传播时延包括所述第一雷达信号对应的第一传播时延。
- 根据权利要求1所述的方法,其特征在于,所述至少一个回波时延包含第二回波时延,所述第二回波时延为第二雷达探测装置的最大探测距离对应的回波时延,和/或,所述至少一个传播时延包含第二传播时延,所述第二传播时延为第三雷达探测装置对应的第三雷达信号对应的传播时延;其中,所述第二回波时延不等于所述第一回波时延,所述第二传播时延不等于所述第一传播时延。
- 根据权利要求1或2所述的方法,其特征在于,所述第一阈值为多个第一子阈值中的最大值,所述多个第一子阈值为根据所述至少一个回波时延和所述至少一个传播时延确定的。
- 根据权利要求1~3任一项所述的方法,其特征在于,所述第一阈值满足如下公式:或,


 其中,为第四雷达探测装置的最大探测距离所对应的回波时延,
 为第五雷达探测装置的最大探测距离所对应的回波时延,
 为第四雷达信号对应的传播时延,
 为第五雷达信号对应的传播时延,a 1为所述第四雷达信号在单位时间内的频率变化量,a 2为所述第五雷达信号在单位时间内的频率变化量,T c为所述第四雷达探测装置的扫频时间,所述第四雷达信号对应于所述第四雷达探测装置,所述第五雷达信号对应于所述第五雷达探测装置,Δ为时间余量,或为同步误差,或为时间余量与同步误差之和,所述同步误差为所述第四雷达探测装置和所述第五雷达探测装置之间的同步误差。

- 根据权利要求1~4任一项所述的方法,其特征在于,所述第二阈值是根据所述至少一个回波时延和所述至少一个传播时延确定的。
- 根据权利要求1~5任一项所述的方法,其特征在于,所述第二阈值为多个第二子阈值中的最小值,所述多个第二子阈值为根据所述至少一个回波时延和所述至少一个传播时延确定的。
- 根据权利要求1~6任一项所述的方法,其特征在于,所述第二阈值满足如下公式:或,


 其中,为第六雷达探测装置的最大探测距离所对应的回波时延,
 为第七雷达探测装置的最大探测距离所对应的回波时延,
 为第六雷达信号对应的传播时延,
 为第七雷达信号对应的传播时延,a 1为所述第六雷达信号在单位时间内的频率变化量,a 2为所述第七雷达信号在单位时间内的频率变化量,T c为所述第六雷达探测装置的扫频时间,所述第六雷达信号对应于所述第六雷达探测装置,所述第七雷达信号对应于所述第七雷达探测装置,Δ为时间余量,或为同步误差,或为时间余量与同步误差之和,所述同步误差为所述第六雷达探测装置和所述第七雷达探测装置之间的同步误差。

- 根据权利要求7所述的方法,其特征在于,所述第六雷达信号对应的传播时延为所述第六雷达信号对应的最大传播时延,所述第七雷达信号对应的传播时延为所述第七雷达信号对应的最大传播时延。
- 根据权利要求1~3任一项所述的方法,其特征在于,所述第一阈值满足如下公式:或者

 其中,为第四雷达探测装置的最大探测距离所对应的回波时延,
 为第五雷达探测装置的最大探测距离所对应的回波时延,
 为第四雷达信号对应的传播时延,
 为第五雷达信号对应的传播时延,a 1为所述第四雷达信号在单位时间内的频率变化量,a 2为所述第五雷达信号在单位时间内的频率变化量,T c为所述第四雷达探测装置的扫频时间,所述第四雷达信号对应于所述第四雷达探测装置,所述第五雷达信号对应于所述第五雷达探测装置,Δ为时间余量,或为同步误差,或为时间余量与同步误差之和,所述同步误差为所述第四雷达探测装置和所述第五雷达探测装置之间的同步误差。

- 根据权利要求1~3或9任一项所述的方法,其特征在于,所述第二阈值是根据所述至少一个回波时延和所述至少一个传播时延确定的。
- 根据权利要求1~3、9、10任一项所述的方法,其特征在于,所述第二阈值为多个第二子阈值中的最小值,所述多个第二子阈值为根据所述至少一个回波时延和所述至少一个传播时延确定的。
- 根据权利要求1~3、9~11任一项所述的方法,其特征在于,所述第二阈值满足如下公式:或,


 其中,为第六雷达探测装置的最大探测距离所对应的回波时延,
 为第七雷 达探测装置的最大探测距离所对应的回波时延,
 为第六雷达信号对应的传播时延,
 为第七雷达信号对应的传播时延,a 1为第六雷达信号在单位时间内的频率变化量,a 2为第七雷达信号在单位时间内的频率变化量,T c为所述第六雷达探测装置的扫频时间,所述第六雷达信号对应于所述第六雷达探测装置,所述第七雷达信号对应于所述第七雷达探测装置,Δ为时间余量,或为同步误差,或为时间余量与同步误差之和,所述同步误差为所述第六雷达探测装置和所述第七雷达探测装置之间的同步误差。

- 根据权利要求9或12所述的方法,其特征在于,所述第四雷达信号对应的传播时延为所述第四雷达信号从所述第四雷达探测装置到达所述第五雷达探测装置的时延,所述第五雷达信号对应的传播时延为所述第五雷达信号从所述第五雷达探测装置到达所述第四雷达探测装置的时延。
- 一种雷达探测装置,其特征在于,包括:处理单元,用于确定第一时域范围,所述第一时域范围为L个时域范围中的时域范围,所述L为大于1的正整数;收发单元,用于在所述第一时域范围内发送第一雷达信号;其中,所述L个时域范围中的任一个时域范围与其它L-1个时域范围中的至少一个时域范围部分重叠,所述L个时域范围中任两个时域范围的时域起始位置的差值的绝对值大于或等于第一阈值且小于或等于第二阈值;所述第一阈值是根据至少一个回波时延和至少一个传播时延确定的,所述至少一个回波时延包含所述雷达探测装置的最大探测距离对应的第一回波时延,所述至少一个传播时延包括所述第一雷达信号对应的第一传播时延。
- 根据权利要求14所述的雷达探测装置,其特征在于,所述至少一个回波时延包含第二回波时延,所述第二回波时延为第二雷达探测装置的最大探测距离对应的回波时延,和/或,所述至少一个传播时延包含第二传播时延,所述第二传播时延为第三雷达探测装置对应的第三雷达信号对应的传播时延;其中,所述第二回波时延不等于所述第一回波时延,所述第二传播时延不等于所述第一传播时延。
- 根据权利要求14或15所述的雷达探测装置,其特征在于,所述第一阈值为多个第一子阈值中的最大值,所述多个第一子阈值为根据所述至少一个回波时延和所述至少一个传播时延确定的。
- 根据权利要求14~16任一项所述的雷达探测装置,其特征在于,所述第一阈值满足如下公式:或,
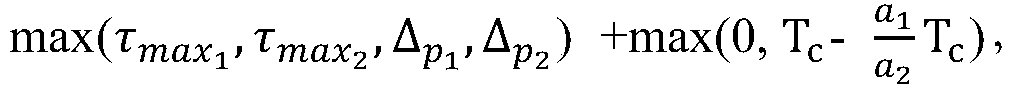

 其中,为第四雷达探测装置的最大探测距离所对应的回波时延,
 为第五雷达探测装置的最大探测距离所对应的回波时延,
 为第四雷达信号对应的传播时延,
 为第五雷达信号对应的传播时延,a 1为所述第四雷达信号在单位时间内的频率变化量, a 2为所述第五雷达信号在单位时间内的频率变化量,T c为所述第四雷达探测装置的扫频时间,所述第四雷达信号对应于所述第四雷达探测装置,所述第五雷达信号对应于所述第五雷达探测装置,Δ为时间余量,或为同步误差,或为时间余量与同步误差之和,所述同步误差为所述第四雷达探测装置和所述第五雷达探测装置之间的同步误差。

- 根据权利要求14~17任一项所述的雷达探测装置,其特征在于,所述第二阈值是根据所述至少一个回波时延和所述至少一个传播时延确定的。
- 根据权利要求14~18任一项所述的雷达探测装置,其特征在于,所述第二阈值为多个第二子阈值中的最小值,所述多个第二子阈值为根据所述至少一个回波时延和所述至少一个传播时延确定的。
- 根据权利要求14~19任一项所述的雷达探测装置,其特征在于,所述第二阈值满足如下公式:或,


 其中,为第六雷达探测装置的最大探测距离所对应的回波时延,
 为第七雷达探测装置的最大探测距离所对应的回波时延,
 为第六雷达信号对应的传播时延,
 为第七雷达信号对应的传播时延,a 1为所述第六雷达信号在单位时间内的频率变化量,a 2为所述第七雷达信号在单位时间内的频率变化量,T c为所述第六雷达探测装置的扫频时间,所述第六雷达信号对应于所述第六雷达探测装置,所述第七雷达信号对应于所述第七雷达探测装置,Δ为时间余量,或为同步误差,或为时间余量与同步误差之和,所述同步误差为所述第六雷达探测装置和所述第七雷达探测装置之间的同步误差。

- 根据权利要求17或20所述的雷达探测装置,其特征在于,所述第四雷达信号对应的传播时延为所述第四雷达信号对应的最大传播时延,所述第五雷达信号对应的传播时延为所述第五雷达信号对应的最大传播时延。
- 根据权利要求14~16任一项所述的雷达探测装置,其特征在于,所述第一阈值满足如下公式:或者

 其中,为第四雷达探测装置的最大探测距离所对应的回波时延,
 为第五雷达探测装置的最大探测距离所对应的回波时延,
 为第四雷达信号对应的传播时延,
 为第五雷达信号对应的传播时延,a 1为所述第四雷达信号在单位时间内的频率变化量,a 2为所述第五雷达信号在单位时间内的频率变化量,T c为所述第四雷达探测装置的扫频时间,所述第四雷达信号对应于所述第四雷达探测装置,所述第五雷达信号对应于所述第五雷达探测装置,Δ为时间余量,或为同步误差,或为时间余量与同步误差之和,所述同步 误差为所述第四雷达探测装置和所述第五雷达探测装置之间的同步误差。

- 根据权利要求14~16或22任一项所述的雷达探测装置,其特征在于,所述第二阈值是根据所述至少一个回波时延和所述至少一个传播时延确定的。
- 根据权利要求14~16、22、23任一项所述的雷达探测装置,其特征在于,所述第二阈值为多个第二子阈值中的最小值,所述多个第二子阈值为根据所述至少一个回波时延和所述至少一个传播时延确定的。
- 根据权利要求14~16、22~24任一项所述的雷达探测装置,其特征在于,所述第二阈值满足如下公式:或,


 其中,为第六雷达探测装置的最大探测距离所对应的回波时延,
 为第七雷达探测装置的最大探测距离所对应的回波时延,
 为第六雷达信号对应的传播时延,
 为第七雷达信号对应的传播时延,a 1为第六雷达信号在单位时间内的频率变化量,a 2为第七雷达信号在单位时间内的频率变化量,T c为所述第六雷达探测装置的扫频时间,所述第六雷达信号对应于所述第六雷达探测装置,所述第七雷达信号对应于所述第七雷达探测装置,Δ为时间余量,或为同步误差,或为时间余量与同步误差之和,所述同步误差为所述第六雷达探测装置和所述第七雷达探测装置之间的同步误差。

- 根据权利要求25所述的雷达探测装置,其特征在于,所述第六雷达信号对应的传播时延为所述第六雷达信号从所述第六雷达探测装置到达所述第七雷达探测装置的时延,所述第七雷达信号对应的传播时延为所述第七雷达信号从所述第七雷达探测装置到达所述第六雷达探测装置的时延。
- 一种计算机可读存储介质,其特征在于,所述计算机可读存储介质存储有计算机程序,当所述计算机程序在计算机上运行时,使得所述计算机执行如权利要求1~13中任意一项所述的方法。
- 一种芯片系统,其特征在于,所述芯片系统包括:存储器:用于存储指令;处理器,用于从所述存储器中调用并运行所述指令,使得安装有所述芯片系统的通信设备执行如权利要求1~13中任意一项所述的方法。
- 一种计算机程序产品,其特征在于,所述计算机程序产品包括计算机程序,当所述计算机程序在计算机上运行时,使得计算机执行如权利要求1~13中任意一项所述的方法。
Priority Applications (3)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| EP20815493.0A EP3968043A4 (en) | 2019-05-31 | 2020-03-03 | RADAR SIGNAL TRANSMISSION METHOD AND DEVICE |
| JP2021570950A JP7451566B2 (ja) | 2019-05-31 | 2020-03-03 | レーダ信号送信方法およびデバイス |
| US17/537,269 US12259491B2 (en) | 2019-05-31 | 2021-11-29 | Radar signal sending method and device |
Applications Claiming Priority (2)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| CN201910473501.4 | 2019-05-31 | ||
| CN201910473501.4A CN112014800B (zh) | 2019-05-31 | 2019-05-31 | 一种雷达信号发送方法及设备 |
Related Child Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| US17/537,269 Continuation US12259491B2 (en) | 2019-05-31 | 2021-11-29 | Radar signal sending method and device |
Publications (1)
| Publication Number | Publication Date |
|---|---|
| WO2020238311A1 true WO2020238311A1 (zh) | 2020-12-03 |
Family
ID=73506436
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| PCT/CN2020/077653 Ceased WO2020238311A1 (zh) | 2019-05-31 | 2020-03-03 | 一种雷达信号发送方法及设备 |
Country Status (5)
| Country | Link |
|---|---|
| US (1) | US12259491B2 (zh) |
| EP (1) | EP3968043A4 (zh) |
| JP (1) | JP7451566B2 (zh) |
| CN (1) | CN112014800B (zh) |
| WO (1) | WO2020238311A1 (zh) |
Cited By (1)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN117641644A (zh) * | 2023-12-28 | 2024-03-01 | 重庆南天智能设施有限公司 | 一种基于雷达传感的智能按需照明控制系统 |
Families Citing this family (4)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| EP3757597B1 (en) * | 2019-06-26 | 2025-10-08 | NXP USA, Inc. | Interference mitigation for radar sensor and radar sensor ic |
| CN113189546B (zh) * | 2021-04-02 | 2024-08-09 | 深圳成谷科技有限公司 | 一种防止雷达干扰的方法、系统及设备 |
| DE102022205168A1 (de) * | 2022-05-24 | 2023-11-30 | Robert Bosch Gesellschaft mit beschränkter Haftung | Verfahren und Vorrichtung zum Betreiben eines automatisierten Fahrzeugs |
| CN118409293B (zh) * | 2024-06-27 | 2024-10-22 | 中国人民解放军海军航空大学 | 一种分数阶域特征目标检测方法、装置及介质 |
Citations (6)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN1894596A (zh) * | 2003-12-19 | 2007-01-10 | 罗伯特·博世有限公司 | 具有两个或多个传感器的系统 |
| CN102356332A (zh) * | 2009-04-06 | 2012-02-15 | 康蒂特米克微电子有限公司 | 具有用于使发送和接收信号分离以及抑制干扰辐射的装置和方法的雷达系统 |
| JP2012107947A (ja) * | 2010-11-16 | 2012-06-07 | Panasonic Corp | レーダ装置 |
| CN102608581A (zh) * | 2011-01-12 | 2012-07-25 | 株式会社万都 | 目标物体检测方法及雷达装置 |
| CN105842700A (zh) * | 2015-01-30 | 2016-08-10 | 现代摩比斯株式会社 | 车辆雷达系统及控制其的方法 |
| US20180252809A1 (en) * | 2016-04-07 | 2018-09-06 | Uhnder, Inc. | Software defined automotive radar |
Family Cites Families (14)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| FR2443070A1 (fr) * | 1978-12-01 | 1980-06-27 | Trt Telecom Radio Electr | Dispositif de radar destine a fournir des informations de distance et de vitesse concernant une cible se deplacant par rapport a lui |
| JP2001255371A (ja) | 2000-03-08 | 2001-09-21 | Mitsubishi Electric Corp | 車両用距離測定装置 |
| JP3838432B2 (ja) * | 2002-02-08 | 2006-10-25 | オムロン株式会社 | 測距装置 |
| JP4462060B2 (ja) | 2005-02-14 | 2010-05-12 | 株式会社デンソー | Fmcwレーダ装置 |
| JP2007187632A (ja) | 2006-01-16 | 2007-07-26 | Fujitsu Ten Ltd | レーダー装置 |
| JP4492628B2 (ja) | 2007-03-20 | 2010-06-30 | 株式会社デンソー | 干渉判定方法,fmcwレーダ |
| JP5317004B1 (ja) | 2012-12-25 | 2013-10-16 | 株式会社パル技研 | 設置用センサ |
| DE102013210256A1 (de) * | 2013-06-03 | 2014-12-04 | Robert Bosch Gmbh | Interferenzunterdrückung bei einem fmcw-radar |
| JP6195278B2 (ja) | 2015-06-11 | 2017-09-13 | 国立研究開発法人 海上・港湾・航空技術研究所 | レーダ装置における相互干渉を回避する方法及びこの方法を用いた監視装置。 |
| JP2017215236A (ja) * | 2016-06-01 | 2017-12-07 | パナソニックIpマネジメント株式会社 | レーダ装置および異常判定方法 |
| JP2018059871A (ja) | 2016-10-07 | 2018-04-12 | 日本信号株式会社 | レーダシステム |
| US11588567B2 (en) * | 2016-12-02 | 2023-02-21 | Texas Instruments Incorporated | Synchronizing vehicle devices over a controller area network |
| US10605892B2 (en) * | 2017-11-08 | 2020-03-31 | GM Global Technology Operations LLC | System and method for pseudo randomized chirp scheduling for interference avoidance |
| US11175376B2 (en) * | 2018-09-18 | 2021-11-16 | Infineon Technologies Ag | System and method for determining interference in a radar system |
-
2019
- 2019-05-31 CN CN201910473501.4A patent/CN112014800B/zh active Active
-
2020
- 2020-03-03 JP JP2021570950A patent/JP7451566B2/ja active Active
- 2020-03-03 WO PCT/CN2020/077653 patent/WO2020238311A1/zh not_active Ceased
- 2020-03-03 EP EP20815493.0A patent/EP3968043A4/en active Pending
-
2021
- 2021-11-29 US US17/537,269 patent/US12259491B2/en active Active
Patent Citations (6)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN1894596A (zh) * | 2003-12-19 | 2007-01-10 | 罗伯特·博世有限公司 | 具有两个或多个传感器的系统 |
| CN102356332A (zh) * | 2009-04-06 | 2012-02-15 | 康蒂特米克微电子有限公司 | 具有用于使发送和接收信号分离以及抑制干扰辐射的装置和方法的雷达系统 |
| JP2012107947A (ja) * | 2010-11-16 | 2012-06-07 | Panasonic Corp | レーダ装置 |
| CN102608581A (zh) * | 2011-01-12 | 2012-07-25 | 株式会社万都 | 目标物体检测方法及雷达装置 |
| CN105842700A (zh) * | 2015-01-30 | 2016-08-10 | 现代摩比斯株式会社 | 车辆雷达系统及控制其的方法 |
| US20180252809A1 (en) * | 2016-04-07 | 2018-09-06 | Uhnder, Inc. | Software defined automotive radar |
Non-Patent Citations (1)
| Title |
|---|
| See also references of EP3968043A4 * |
Cited By (1)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN117641644A (zh) * | 2023-12-28 | 2024-03-01 | 重庆南天智能设施有限公司 | 一种基于雷达传感的智能按需照明控制系统 |
Also Published As
| Publication number | Publication date |
|---|---|
| EP3968043A1 (en) | 2022-03-16 |
| JP7451566B2 (ja) | 2024-03-18 |
| CN112014800B (zh) | 2022-12-02 |
| US12259491B2 (en) | 2025-03-25 |
| EP3968043A4 (en) | 2022-06-22 |
| JP2022534996A (ja) | 2022-08-04 |
| US20220082655A1 (en) | 2022-03-17 |
| CN112014800A (zh) | 2020-12-01 |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| WO2020259636A1 (zh) | 一种通信方法及装置 | |
| US11754668B2 (en) | Detection method, detection apparatus, and system | |
| US11971468B2 (en) | Method for detecting target object and corresponding detection apparatus | |
| US12436229B2 (en) | Signal processing method and apparatus, and storage medium | |
| CN111638519B (zh) | 一种利用无线电信号进行目标物探测的方法及相关装置 | |
| WO2021032000A1 (zh) | 一种信号发射方法及装置 | |
| WO2021008139A1 (zh) | 一种检测方法、信号发送方法及装置 | |
| US12259491B2 (en) | Radar signal sending method and device | |
| US12210113B2 (en) | Radio signal sending method and apparatus | |
| US12517243B2 (en) | Information reporting method, information receiving method, and apparatus | |
| US20220326369A1 (en) | Frequency Band State Determining Method and Related Device |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| 121 | Ep: the epo has been informed by wipo that ep was designated in this application |
Ref document number: 20815493 Country of ref document: EP Kind code of ref document: A1 |
|
| ENP | Entry into the national phase |
Ref document number: 2021570950 Country of ref document: JP Kind code of ref document: A |
|
| NENP | Non-entry into the national phase |
Ref country code: DE |
|
| ENP | Entry into the national phase |
Ref document number: 2020815493 Country of ref document: EP Effective date: 20211207 |