WO2021196764A1 - 到达时间的确定方法、装置、信号接收设备及存储介质 - Google Patents
到达时间的确定方法、装置、信号接收设备及存储介质 Download PDFInfo
- Publication number
- WO2021196764A1 WO2021196764A1 PCT/CN2020/138462 CN2020138462W WO2021196764A1 WO 2021196764 A1 WO2021196764 A1 WO 2021196764A1 CN 2020138462 W CN2020138462 W CN 2020138462W WO 2021196764 A1 WO2021196764 A1 WO 2021196764A1
- Authority
- WO
- WIPO (PCT)
- Prior art keywords
- arrival time
- leading edge
- correction information
- slope
- arrival
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Ceased
Links
Images



Classifications
-
- H—ELECTRICITY
- H04—ELECTRIC COMMUNICATION TECHNIQUE
- H04W—WIRELESS COMMUNICATION NETWORKS
- H04W4/00—Services specially adapted for wireless communication networks; Facilities therefor
- H04W4/02—Services making use of location information
-
- G—PHYSICS
- G01—MEASURING; TESTING
- G01S—RADIO DIRECTION-FINDING; RADIO NAVIGATION; DETERMINING DISTANCE OR VELOCITY BY USE OF RADIO WAVES; LOCATING OR PRESENCE-DETECTING BY USE OF THE REFLECTION OR RERADIATION OF RADIO WAVES; ANALOGOUS ARRANGEMENTS USING OTHER WAVES
- G01S5/00—Position-fixing by co-ordinating two or more direction or position line determinations; Position-fixing by co-ordinating two or more distance determinations
- G01S5/02—Position-fixing by co-ordinating two or more direction or position line determinations; Position-fixing by co-ordinating two or more distance determinations using radio waves
- G01S5/0205—Details
- G01S5/0218—Multipath in signal reception
-
- G—PHYSICS
- G01—MEASURING; TESTING
- G01S—RADIO DIRECTION-FINDING; RADIO NAVIGATION; DETERMINING DISTANCE OR VELOCITY BY USE OF RADIO WAVES; LOCATING OR PRESENCE-DETECTING BY USE OF THE REFLECTION OR RERADIATION OF RADIO WAVES; ANALOGOUS ARRANGEMENTS USING OTHER WAVES
- G01S5/00—Position-fixing by co-ordinating two or more direction or position line determinations; Position-fixing by co-ordinating two or more distance determinations
- G01S5/02—Position-fixing by co-ordinating two or more direction or position line determinations; Position-fixing by co-ordinating two or more distance determinations using radio waves
- G01S5/0205—Details
- G01S5/0221—Receivers
-
- H—ELECTRICITY
- H04—ELECTRIC COMMUNICATION TECHNIQUE
- H04W—WIRELESS COMMUNICATION NETWORKS
- H04W64/00—Locating users or terminals or network equipment for network management purposes, e.g. mobility management
-
- G—PHYSICS
- G01—MEASURING; TESTING
- G01S—RADIO DIRECTION-FINDING; RADIO NAVIGATION; DETERMINING DISTANCE OR VELOCITY BY USE OF RADIO WAVES; LOCATING OR PRESENCE-DETECTING BY USE OF THE REFLECTION OR RERADIATION OF RADIO WAVES; ANALOGOUS ARRANGEMENTS USING OTHER WAVES
- G01S11/00—Systems for determining distance or velocity not using reflection or reradiation
- G01S11/02—Systems for determining distance or velocity not using reflection or reradiation using radio waves
-
- G—PHYSICS
- G01—MEASURING; TESTING
- G01S—RADIO DIRECTION-FINDING; RADIO NAVIGATION; DETERMINING DISTANCE OR VELOCITY BY USE OF RADIO WAVES; LOCATING OR PRESENCE-DETECTING BY USE OF THE REFLECTION OR RERADIATION OF RADIO WAVES; ANALOGOUS ARRANGEMENTS USING OTHER WAVES
- G01S5/00—Position-fixing by co-ordinating two or more direction or position line determinations; Position-fixing by co-ordinating two or more distance determinations
- G01S5/02—Position-fixing by co-ordinating two or more direction or position line determinations; Position-fixing by co-ordinating two or more distance determinations using radio waves
- G01S5/06—Position of source determined by co-ordinating a plurality of position lines defined by path-difference measurements
Definitions
- This application relates to the field of wireless communication systems, for example, to a method, device, signal receiving device, and storage medium for determining the arrival time.
- the time difference of arrival (TDOA) positioning method is generally used for the high-precision positioning of devices in the communication network, that is, the distance between the sender and the receiver is determined by measuring the time when the signal reaches the receiver. The distance from the signal source to each receiving end can determine the location of the signal source.
- the TDOA positioning method is mainly to determine the frame header and define Orthogonal Frequency Division Multiplexing (OFDM) symbols. From the defined time point, remove the fixed number of sampling points according to the prefix length to obtain the symbol time domain data, and then proceed In mathematical sequence correlation operation, the first largest correlation peak is taken as the time of arrival of the signal (Time of Arrival).
- the detection of TOA is usually based on the theoretical autocorrelation triangle waveform of the signal.
- This application provides a method, a device, a signal receiving device, and a storage medium for determining arrival time, so as to improve the accuracy and reliability of arrival time detection.
- the embodiment of the present application provides a method for determining the arrival time, including:
- the embodiment of the present application also provides a device for determining the arrival time, including:
- the correction information generation module is set to generate the arrival time correction information according to the leading edge information of the theoretical autocorrelation waveform of the positioning signal with different fading values; the leading edge slope calculation module is set to calculate the leading edge slope corresponding to the leading edge reference point of the relevant waveform of the actual received signal.
- the arrival time determination module is configured to determine target correction information from the arrival time correction information according to the leading edge slope, and determine the arrival time of the actual received signal based on the target correction information.
- the embodiment of the present application also provides a signal receiving device, including:
- One or more processors a storage device for storing one or more programs; when the one or more programs are executed by the one or more processors, the one or more processors can realize the above How to determine the arrival time.
- the embodiment of the present application also provides a computer-readable storage medium, and a computer program is stored on the computer-readable storage medium, and when the program is executed by a processor, the above-mentioned method for determining the arrival time is realized.
- Figure 1 is a schematic diagram of actual received signals in the case of multipath transmission
- FIG. 2 is a flowchart of a method for determining arrival time according to an embodiment
- FIG. 3 is a flowchart of another method for determining arrival time according to an embodiment
- FIG. 4 is a schematic diagram of theoretical autocorrelation waveforms of m first bisectors and n positioning signals according to an embodiment
- FIG. 5 is a schematic diagram of detecting the leading edge slope of a single path signal according to an embodiment
- FIG. 6 is a schematic diagram of detecting the leading edge slope of a multipath signal according to an embodiment
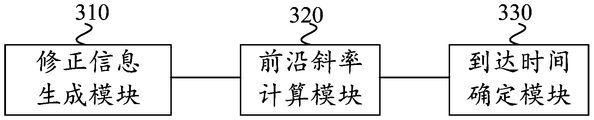
- FIG. 7 is a schematic structural diagram of an apparatus for determining arrival time provided by an embodiment
- FIG. 8 is a schematic diagram of the hardware structure of a signal receiving device provided by an embodiment.
- the detection of the arrival time is usually based on the detection of the slope of the signal's theoretical autocorrelation triangle waveform, for example, the first largest correlation peak is taken as the arrival time of the signal .
- the slope of the signal-related waveforms will often be distorted.
- Fig. 1 is a schematic diagram of the actual received signal in the case of multipath transmission.
- the case of signal multipath transmission is taken as an example.
- the dotted line represents the result of multipath transmission of the signal, and the solid line represents the signal waveform actually received by the receiving end.
- the relevant waveform of the actual received signal is obviously not an ideal triangle. Waveform, so the method based on slope detection to determine the arrival time of the signal has a very large error.
- the instability of channel quality and the influence of other noises or bandwidth limitations may result in large errors in the slope detection method, which makes it impossible to achieve high-precision time-of-arrival measurement under complex wireless environments and bandwidth limitations.
- the accuracy of measuring the arrival time based on the slope is low, and the arrival time correction information is generated according to the theoretical autocorrelation waveform of the positioning signal, and the theoretical arrival time correction information has some effect on the actual received signal.
- the time amount of the leading edge position can be corrected to focus on the details of the leading edge change of the actual received signal in a multipath or noisy environment, so that the detection result of the leading edge slope of the actual received signal is closer to the theoretical waveform, thereby improving the accuracy and accuracy of the arrival time detection. reliability.
- Fig. 2 is a flowchart of a method for determining arrival time provided in an embodiment. As shown in Fig. 2, the method provided in this embodiment includes steps 110-140.
- step 110 the time-of-arrival correction information is generated according to the leading edge information of the theoretical autocorrelation waveforms of the positioning signals with different fading values.
- step 120 the leading edge slope corresponding to the leading edge reference point of the relevant waveform of the actual received signal is calculated.
- target correction information is determined from the arrival time correction information according to the leading edge slope.
- step 140 the arrival time of the actual received signal is determined based on the target correction information.
- the frontier information of the theoretical autocorrelation waveform of the positioning signal is used to generate the arrival time correction information, where there may be multiple theoretical autocorrelation waveforms of the positioning signal, which respectively correspond to different fading values.
- the theoretical autocorrelation waveform of the positioning signal corresponding to different fading values is divided into several segments, and several reference points on the leading edge of the theoretical autocorrelation wave can be determined according to the division result. According to the corresponding time at each reference point The amount can generate the arrival time correction information.
- the arrival time correction information can be stored in the form of a table. Each item in the arrival time correction information corresponds to a reference point, and the leading edge information of the reference point is recorded.
- the leading edge information can include slope and time amount, etc., generated according to the theoretical autocorrelation waveform
- the time-of-arrival correction information is in line with the transmission result of the signal in an ideal state.
- the corresponding slope may be different at the positions corresponding to the above-mentioned reference points, and the corresponding amount of time is not accurate. Therefore, it is inaccurate to determine the arrival time through slope detection.
- the target correction information at the position corresponding to the leading edge reference point is searched in the arrival time correction information.
- the amount of time is corrected.
- the earliest time in the corrected time amount corresponding to each frontier reference point can be obtained (it can also be based on the earliest time or the earliest type of time amount, obtained through mathematical statistics.
- the average amount of time, etc. is used as the arrival time, thereby reducing the error of the arrival time of the actual received signal based on the slope detection.
- the fading value of the positioning signal may be divided into several different values according to a certain rule to obtain positioning signals corresponding to different fading values. For example, if the positioning signal is normalized, the maximum fading value is 1, and the fading value is divided into three cases. Taking the three-division fading value as an example, the fading value of the positioning signal is 1, 2/3, 1/ 3. Obtain the theoretical autocorrelation waveforms of the three positioning signals; for the theoretical autocorrelation waveforms of each positioning signal, it can be divided into several segments according to certain rules, so as to determine several reference points on the leading edge, according to the corresponding reference points The slope and the amount of time generate the arrival time correction information.
- the relevant waveform of the actual received signal it can be divided into several segments according to the same rule to obtain corresponding several leading edge reference points. According to the leading edge slope of each leading edge reference point, the closest one is determined from the arrival time correction information.
- the item is the target correction information corresponding to the front reference point.
- the theoretical autocorrelation waveform of the positioning signal is normalized according to the modulus value or the fading value, and the correlation waveform of the actual received signal is normalized according to the modulus value, thereby facilitating the selection of reference points and reducing the amount of calculation.
- the arrival time determination method of this embodiment generates arrival time correction information based on the theoretical autocorrelation waveform of the positioning signal, and corrects the leading edge reference point of the actual received signal according to the theoretical arrival time correction information, based on the corrected actual received signal correlation waveform
- the data to determine the arrival time can focus on the front change details of the actual received signal related waveform in a multipath or noisy environment, so that the detection result of the front slope of the actual received signal is closer to the theoretical waveform, thereby improving the accuracy and reliability of the arrival time detection .
- Fig. 3 is a flowchart of another method for determining arrival time provided by an embodiment. As shown in Fig. 3, the method provided by this embodiment includes steps 210-270.
- step 210 the autocorrelation waveform of the normalized positioning signal is equally divided according to the fading value n, and theoretical autocorrelation waveforms of n positioning signals corresponding to different fading values are obtained.
- step 220 the height m of the leading edge of the autocorrelation waveform of the normalized positioning signal is equally divided to obtain m first bisectors.
- step 230 the arrival time correction information is generated according to the theoretical autocorrelation waveforms of the m first bisectors and the n positioning signals.
- the positioning signal is normalized according to the modulus value, that is, the maximum modulus value is 1, and the autocorrelation waveform of the normalized positioning signal is divided equally according to the fading value n, which means: Correlation waveforms are divided into n cases, in order: the maximum modulus value of the autocorrelation function is 1, the maximum modulus value of the autocorrelation function is (n-1)/n, ..., and the maximum modulus value of the autocorrelation function is 1. In the case of /n, there are a total of n positioning signals corresponding to different fading values.
- the autocorrelation waveform of the normalized positioning signal is divided into m equal parts from 0 to 1 according to the height of the leading edge, and m first bisectors are obtained, and the height of each part is 1/m.
- FIG. 4 is a schematic diagram of theoretical autocorrelation waveforms of m first bisectors and n positioning signals according to an embodiment.
- the leading edge heights corresponding to the m first bisectors are 1/m, 2/m,..., m/m from bottom to top;
- step 240 the leading edge slope corresponding to the leading edge reference point of the relevant waveform of the actual received signal is calculated.
- some leading edge reference points are selected, for example, the intersection points on the leading edge are obtained by m equal division of the relevant waveform of the actual received signal according to the modulus, and the leading edge slopes of these intersection points are calculated.
- the rule for selecting the leading edge reference point for the actual received signal is consistent with the rule for selecting the reference point for the theoretical autocorrelation waveform of the positioning signal, so that the correction of the actual received signal is closer to the theoretical autocorrelation waveform, and the correction information is more closely matched with the actual received signal , Improve the accuracy of arrival time detection.
- step 250 the target correction information is searched in the arrival time correction information according to the slope of each leading edge, and the target correction information includes the standard slope corresponding to each leading edge slope and the correction value of the arrival time corresponding to each standard slope.
- step 260 the candidate arrival time corresponding to each leading edge slope is calculated according to each arrival time correction value.
- step 270 the arrival time of the actual received signal is determined according to the arrival time of each candidate.
- the m modified arrival times that is, the candidate arrival times
- the candidate arrival times are sequentially obtained, and the candidate arrival times are clustered, averaged, etc. Therefore, the candidate arrival time corresponding to the cluster with the earliest time (the smallest value of time) can be used as the arrival time of the actual received signal.
- the autocorrelation waveform of the normalized positioning signal is an autocorrelation waveform normalized according to the modulus value; the maximum modulus value of the theoretical autocorrelation waveforms of n positioning signals is 1, and the minimum value is It is 1/n; m and n are negatively correlated with the accuracy of arrival time correction respectively.
- the theoretical autocorrelation waveform of the normalized positioning signal is divided into equal parts according to the leading edge height m and equal parts according to the fading value n.
- the values of m and n can be determined through simulation.
- the reference points on the theoretical autocorrelation waveform of various fading values can also be divided and selected according to other rules, not necessarily in the form of dividing the front height into equal parts.
- the comparison can be performed according to the statistical law of amplitude. The steep (high change rate of the leading edge) or the larger amplitude of the leading edge is divided into more segments, and more reference points are determined to obtain a more dense and accurate standard slope and arrival time correction value; while for the relatively flat (leading edge height)
- the front part with small change rate) or small amplitude can select fewer reference points, which simplifies the calculation to a certain extent.
- the arrival time correction information includes a standard slope and an arrival time correction value.
- Step 230 includes:
- Step 231 Calculate the standard slope corresponding to the intersection of each of the first bisectors and the leading edge of the theoretical autocorrelation waveform of each of the positioning signals.
- Step 232 Determine the arrival time correction value corresponding to each standard slope according to the difference between the time amount corresponding to the maximum modulus value of the autocorrelation waveform of the normalized positioning signal and the time amount corresponding to each of the intersection points.
- the corresponding standard slope at the intersection of the theoretical autocorrelation waveforms of the positioning signal with fading values is denoted as k i,j
- the corresponding arrival time correction value is denoted as ⁇ i,j
- the arrival time correction information is generated
- k i, j is the standard slope in the table entry
- ⁇ i,j is the arrival time correction value
- T max is the amount of time corresponding to the maximum modulus of the theoretical autocorrelation waveform
- T i,j is the maximum modulus of the autocorrelation function j/n , The time value corresponding to the data point where the front height is i/m.
- Table 1 is the time of arrival correction information generated based on the theoretical autocorrelation waveforms of m first bisectors and n positioning signals.
- the arrival time correction information is stored in the form of a table.
- the arrival time correction table can be a two-dimensional table with n types of fading values on the horizontal axis and m types of frontal heights on the vertical axis.
- the table items include standard slope and arrival.
- Time correction value The arrival time correction information corresponding to the theoretical autocorrelation waveform of the i-th first bisector and the j-th fading value positioning signal includes the standard slope k i,j and the arrival time correction value ⁇ ij .
- step 240 includes:
- Step 241 Divide the height m of the leading edge of the relevant waveform of the actual received signal into equal parts to obtain m second bisectors.
- Step 242 Determine m leading edge reference points according to the intersection of the m second bisectors and the leading edge of the relevant waveform of the actual received signal.
- Step 243 Calculate the leading edge slope corresponding to each leading edge reference point respectively.
- the relevant waveform of the actual received signal is equally divided according to the height of the leading edge m to obtain m second bisectors.
- the rule for selecting the leading edge reference point for the actual received signal is consistent with the rule for selecting the reference point for the theoretical autocorrelation waveform of the positioning signal, so that the correction of the actual received signal is closer to the theoretical autocorrelation waveform, and the correction information is consistent with the actual received signal.
- the matching degree is higher, and the detection accuracy of the arrival time is improved.
- each second bisector normalizes the relevant waveform of the actual received signal, the height of each divided into 1/m, and the amplitude corresponding to each second bisector is 1/m, 2/m in turn ,..., m/m, the intersection of each second bisector and the leading edge of the relevant waveform is a leading edge reference point, and there are a total of m reference points corresponding to m leading edge slopes.
- the correlation waveform of the actual received signal is a correlation waveform normalized according to the modulus value.
- the actual received signal is mathematically correlated with the transmission sequence stored locally by the signal receiving device, and the relevant waveform of the actual received signal can be obtained.
- the overall relevant waveform is divided by the maximum modulus value to obtain the normalized autocorrelation. Waveform.
- the front reference point of the actual received waveform can also be selected according to other rules, and not necessarily in the form of dividing the front height into equal parts. For example, it may be relatively steep according to the statistical law of the amplitude (the front height change rate is large) Or the front part with larger amplitude is divided into more segments, and more front-end reference points are determined for more precise correction; and for the front part that is relatively flat (smaller front height change rate) or smaller amplitude, you can choose a more advanced part. Fewer reference points simplifies the calculation to a certain extent.
- step 250 includes:
- the standard slope closest to the leading edge slope in the arrival time correction information is taken as the standard slope corresponding to the leading edge slope, and the corresponding arrival time correction value is read.
- step 260 includes:
- the sum of the actual time corresponding to each leading edge slope and the corresponding arrival time correction value is used as the candidate arrival time corresponding to the leading edge slope.
- step 270 includes:
- Step 271 Establish clusters of each candidate arrival time according to the cluster discrimination threshold, and each cluster includes at least one candidate arrival time.
- Step 272 Determine the arrival time of the actual received signal according to the cluster with the smallest value of the candidate arrival time.
- the x candidate arrival times belong to a cluster, where x is An integer greater than or equal to 2.
- the basis for establishing clustering is that for any TOA i and TOA j , i, j ⁇ [1, m], if it satisfies:
- step 272 includes:
- the average value of the candidate arrival time corresponding to each of the clusters is calculated, and the smallest average value is used as the arrival time of the actual received signal.
- the average value of the candidate arrival time is calculated for each cluster, as the candidate TOA of the cluster, and the smallest cluster refers to the cluster where the smallest candidate TOA is located.
- the smallest candidate TOA is taken as the earliest arrival time of the signal.
- the cluster with the smallest candidate arrival time may also be regarded as the smallest cluster, and the average value of each candidate arrival time corresponding to the smallest cluster may be regarded as the arrival time.
- the following uses single-path signals and multi-path signals as examples to illustrate the time-of-arrival detection process through examples.
- Example 1 Determine the arrival time based on the detection of the leading edge slope for a single path signal
- the positioning signal transmitted by the base station is the positioning reference signal (Positioning Reference Signals, PRS) of the 3rd Generation Partnership Project (3rd Generation Partnership Project, 3GPP) standard.
- PRS Positioning Reference Signals
- 3rd Generation Partnership Project 3GPP 3rd Generation Partnership Project
- PCI Physical Cell Identifier
- the receiving end performs correlation calculations between the actual received signal and the local to obtain the relevant waveform.
- the positioning signal is normalized, and the theoretical autocorrelation waveform of the normalized positioning signal is divided into 10 equal parts according to the previous required height and 20 equal parts according to the fading value to generate the arrival time correction information.
- Table 2 is the generated arrival time correction information table. As shown in Table 2, the correction table includes the corresponding standard slopes and corresponding arrival time correction values under different front edge heights and fading values.
- FIG. 5 is a schematic diagram of detecting the leading edge slope of a single path signal according to an embodiment. In the case that the actual received signal is a single-path signal, there is no multipath influence.
- Cluster the candidate arrival times, and set the cluster discrimination threshold Z 5.
- the difference between the above candidate arrival times is less than 5, and the above candidate arrival times belong to the same cluster. This is due to the single
- the path signal is not affected by multipath transmission, and its related waveform is closer to the ideal state, and the error and fluctuation between the arrival times of each candidate are also small.
- the average value of the candidate arrival time in this cluster is 245760, that is, the final measured TOA is 245760, and the above-mentioned time unit is Ts/30.
- Example 2 Determine the arrival time based on the detection of the leading edge slope for the multipath signal
- the positioning signal transmitted by the base station is a 3GPP standard PRS signal.
- PCI physical cell identifier
- oversampling factor 30.
- a multipath channel with two paths is constructed, the first path has an attenuation of 0.5, the second path has no attenuation, and the delay is 100 (Ts/30).
- FIG. 6 is a schematic diagram of detecting the leading edge slope of a multipath signal according to an embodiment.
- the correlation waveform obtained after the correlation calculation with the local signal is shown in Figure 6, which is divided into 10 equal parts according to the height of the leading edge, and the intersection of each bisecting line and the leading edge is calculated.
- the leading edge slope, there are 10 leading edge slopes, denoted as k r (r 1, 2,..., 10).
- the theoretical autocorrelation waveform of the positioning signal and the correlation waveform of the actual received signal are normalized and divided equally to determine the reference point, so that the theoretical autocorrelation waveform and the correlation waveform of the actual received signal are Corresponding to the corresponding positions, use the theoretical standard slope and the arrival time correction value to correct the front-end reference point time of the actual received signal.
- the arrival time is determined according to the minimum clustering, which can significantly reduce the influence of the bandwidth signal on the slope detection. It can refine the change details of the frontier of the autocorrelation signal of the multipath environment and improve the detection accuracy.
- Fig. 7 is a schematic structural diagram of an apparatus for determining arrival time provided by an embodiment.
- the device for determining the arrival time includes: a correction information generating module 310, a leading edge slope calculation module 320, and an arrival time determining module 330.
- the correction information generating module 310 is set to generate the arrival time correction information according to the leading edge information of the theoretical autocorrelation waveform of the positioning signal with different fading values; the leading edge slope calculation module 320 is set to calculate the corresponding leading edge reference point of the relevant waveform of the actual received signal Leading edge slope; the arrival time determining module 330 is configured to determine target correction information from the arrival time correction information according to the leading edge slope, and to determine the arrival time of the actual received signal based on the target correction information.
- the arrival time determination device of this embodiment generates arrival time correction information according to the theoretical autocorrelation waveform of the positioning signal, and corrects the time amount of some front positions of the actual received signal according to the theoretical arrival time correction information, which can be used in multipath or In a noisy environment, pay attention to the details of the leading edge change of the actual received signal related waveform, so that the detection result of the leading edge slope of the actual received signal is closer to the theoretical waveform, thereby improving the accuracy and reliability of the arrival time detection.
- the correction information generating module 310 includes:
- the first dividing unit is set to divide the autocorrelation waveform of the normalized positioning signal into equal parts according to the fading value n to obtain theoretical autocorrelation waveforms of n positioning signals corresponding to different fading values;
- the second dividing unit is set to The height m of the leading edge of the autocorrelation waveform of the normalized positioning signal is equally divided to obtain m first bisectors;
- the correction unit is set to be based on the m first bisectors and the n positioning signals
- the theoretical autocorrelation waveform of generates the arrival time correction information; where m and n are both integers greater than 2.
- the arrival time correction information includes a standard slope and an arrival time correction value; the correction unit includes:
- the first calculation subunit is set to calculate the standard slope corresponding to the intersection of each of the first bisectors and the leading edge of the theoretical autocorrelation waveform of each of the positioning signals; the second calculation subunit is set to calculate the normalization according to the The difference between the amount of time corresponding to the maximum modulus of the autocorrelation waveform of the positioning signal and the amount of time corresponding to each of the intersection points determines the arrival time correction value corresponding to each of the standard slopes.
- the leading edge slope calculation module 320 includes:
- the third bisector unit is configured to divide the height m of the front edge of the relevant waveform of the actual received signal equally to obtain m second bisectors; the reference point determination unit is configured to be based on the m second bisectors The intersection with the leading edge of the relevant waveform of the actual received signal determines m leading edge reference points; the slope calculation module is configured to calculate the leading edge slope corresponding to each leading edge reference point respectively.
- the arrival time determination module 330 includes:
- a searching unit configured to search for target correction information in the arrival time correction information according to each of the leading edge slopes, where the target correction information includes a standard slope corresponding to each of the leading edge slopes and an arrival time correction corresponding to each of the standard slopes
- the candidate time calculation unit is configured to calculate the candidate arrival time corresponding to each of the leading edge slopes according to each of the arrival time correction values
- the arrival time determination unit is configured to determine the actual reception according to each of the candidate arrival times The arrival time of the signal.
- the search unit is set to:
- the standard slope closest to the leading edge slope in the arrival time correction information is taken as the standard slope corresponding to the leading edge slope, and the corresponding arrival time correction value is read.
- the candidate time calculation unit is set to:
- the sum of the actual time corresponding to each leading edge slope and the corresponding arrival time correction value is used as the candidate arrival time corresponding to the leading edge slope.
- the arrival time determining unit includes:
- the clustering subunit is set to establish clusters of each candidate arrival time according to the cluster discrimination threshold, and each cluster contains at least one candidate arrival time; the time determination subunit is set to take the smallest value according to the candidate arrival time Clustering determines the arrival time of the actual received signal.
- the time determination subunit is set to:
- the average value of each candidate arrival time in the cluster with the smallest candidate arrival time value is used as the arrival time of the actual received signal.
- the x candidate arrival times belong to one cluster, wherein, the x is an integer greater than or equal to 2.
- the autocorrelation waveform of the normalized positioning signal is an autocorrelation waveform normalized according to the modulus; the maximum modulus value of the theoretical autocorrelation waveforms of the n positioning signals is 1. , The minimum value is 1/n; m and n are negatively related to the accuracy of arrival time correction respectively.
- the correlation waveform of the actual received signal is a correlation waveform normalized according to the modulus value.
- the apparatus for determining the arrival time proposed in this embodiment and the method for determining the arrival time proposed in the above embodiments belong to the same application concept.
- this embodiment has the same Perform the same beneficial effect as the method of determining the arrival time.
- the embodiment of the present application also provides a signal receiving device.
- the method for determining the arrival time may be executed by a device for determining the arrival time, and the device for determining the arrival time may be implemented by software and/or hardware, and integrated in the signal receiving device.
- FIG. 8 is a schematic diagram of the hardware structure of a signal receiving device provided by an embodiment.
- a signal receiving device provided in this embodiment includes a processor 410 and a storage device 420. There may be one or more processors in the signal receiving device.
- One processor 410 is taken as an example in FIG. 8.
- the processor 410 and the storage device 420 in the device may be connected by a bus or other means. In FIG. Take the bus connection as an example.
- the one or more programs are executed by the one or more processors 410, so that the one or more processors implement the method for determining the arrival time described in any of the foregoing embodiments.
- the storage device 420 in the signal receiving device is used as a computer-readable storage medium and can be used to store one or more programs.
- the programs can be software programs, computer-executable programs, and modules, such as the arrival time in the embodiment of this application.
- the program instructions/modules corresponding to the determination method include: a correction information generation module 310, a leading edge slope calculation module 320, and an arrival time determination module 330).
- the processor 410 executes various functional applications and data processing of the signal receiving device by running the software programs, instructions, and modules stored in the storage device 420, that is, implements the method for determining the arrival time in the foregoing method embodiment.
- the storage device 420 mainly includes a storage program area and a storage data area.
- the storage program area can store an operating system and an application program required by at least one function; the storage data area can store data created according to the use of the device, etc. In the example, the arrival time correction information, leading edge slope, etc.).
- the storage device 420 may include a high-speed random access memory, and may also include a non-volatile memory, such as at least one magnetic disk storage device, a flash memory device, or other non-volatile solid-state storage devices.
- the storage device 420 may include a memory remotely provided with respect to the processor 410, and these remote memories may be connected to the signal receiving device through a network. Examples of the aforementioned networks include, but are not limited to, the Internet, corporate intranets, local area networks, mobile communication networks, and combinations thereof.
- the following operations are implemented: generating the arrival time according to the leading edge information of the theoretical autocorrelation waveforms of the positioning signals with different fading values Correction information; calculate the leading edge slope corresponding to the leading edge reference point of the relevant waveform of the actual received signal; determine target correction information from the arrival time correction information according to the leading edge slope, and determine the actual received signal based on the target correction information Time of arrival.
- the signal receiving device proposed in this embodiment and the method for determining the arrival time proposed in the above embodiment belong to the same application concept.
- the time determination method has the same beneficial effect.
- the embodiment of the present application also provides a storage medium containing computer-executable instructions.
- a method for determining arrival time is performed.
- the method includes: positioning signals according to different fading values
- the leading edge information of the theoretical autocorrelation waveform generates the arrival time correction information; the leading edge slope corresponding to the leading edge reference point of the relevant waveform of the actual received signal is calculated; the target correction information is determined from the arrival time correction information according to the leading edge slope, and based on The target correction information determines the arrival time of the actual received signal.
- this application can be implemented by software and general-purpose hardware, and can also be implemented by hardware.
- the technical solution of the present application can be embodied in the form of a software product, and the computer software product can be stored in a computer-readable storage medium, such as a computer floppy disk, read-only memory (ROM), Random Access Memory (RAM), flash memory (FLASH), hard disk or optical disk, etc., including multiple instructions to make a computer device (which can be a personal computer, server, or network device, etc.) execute any of this application The method described in the embodiment.
- the block diagram of any logic flow in the drawings of the present application may represent program steps, or may represent interconnected logic circuits, modules, and functions, or may represent a combination of program steps and logic circuits, modules, and functions.
- the computer program can be stored on the memory.
- the memory can be of any type suitable for the local technical environment and can be implemented using any suitable data storage technology, such as but not limited to read only memory (ROM), random access memory (RAM), optical storage devices and systems (digital multi-function optical discs) (Digital Video Disc, DVD) or Compact Disk (CD)), etc.
- Computer-readable media may include non-transitory storage media.
- the data processor can be any type suitable for the local technical environment, such as but not limited to general-purpose computers, special-purpose computers, microprocessors, digital signal processors (Digital Signal Processing, DSP), application specific integrated circuits (ASICs) ), programmable logic devices (Field-Programmable Gate Array, FPGA), and processors based on multi-core processor architecture.
- DSP Digital Signal Processing
- ASICs application specific integrated circuits
- FPGA Field-Programmable Gate Array
- FPGA Field-Programmable Gate Array
Landscapes
- Engineering & Computer Science (AREA)
- Physics & Mathematics (AREA)
- General Physics & Mathematics (AREA)
- Radar, Positioning & Navigation (AREA)
- Remote Sensing (AREA)
- Computer Networks & Wireless Communication (AREA)
- Signal Processing (AREA)
- Position Fixing By Use Of Radio Waves (AREA)
Abstract
本文公开一种到达时间的确定方法、装置、信号接收设备及存储介质。该到达时间的确定方法根据不同衰落值的定位信号的理论自相关波形的前沿信息生成到达时间修正信息;计算实际接收信号的相关波形的前沿参考点对应的前沿斜率;根据所述前沿斜率从所述到达时间修正信息中确定目标修正信息,并基于所述目标修正信息确定所述实际接收信号的到达时间。
Description
本申请要求在2020年04月01日提交中国专利局、申请号为202010251397.7的中国专利申请的优先权,该申请的全部内容通过引用结合在本申请中。
本申请涉及无线通信系统领域,例如涉及一种到达时间的确定方法、装置、信号接收设备及存储介质。
在无线通信系统中,对于通信网络中设备的高精度定位一般采用到达时间差(Time Difference of Arrival,TDOA)定位法,即通过测量信号到达接收端的时间确定发送端与接收端之间的距离,根据信号源到各个接收端的距离可以确定信号源的位置。TDOA定位法主要是确定帧头并界定正交频分复用(Orthogonal Frequency Division Multiplexing,OFDM)符号,从界定的时间点起按照前缀长度去掉固定的采样点数目,得到符号时域数据,然后进行数学序列相关运算,取首个最大相关峰作为信号的到达时间(Time of Arrival)。对于TOA的检测通常是基于信号的理论自相关三角波形进行检测。但随着通信网络环境越来越复杂多变,例如在室内、密集城区等多径复杂的环境下,由于存在噪声和多径的影响,导致信号相关波形的斜率发生畸变,已经不再是理想的三角波形,因此基于斜率检测方法存在非常大的误差;并且在实际应用中带宽是有限的,在带宽受到严格限制的情况下,自相关波形也不再是严格的三角波形,这种情况和多径情况混合在一起,使得信号相关波形更加复杂,基于斜率的检测方法的精度和可靠性偏低。
发明内容
本申请提供一种达时间的确定方法、装置、信号接收设备及存储介质,以提高到达时间检测的精度和可靠性。
本申请实施例提供一种到达时间的确定方法,包括:
根据不同衰落值的定位信号的理论自相关波形的前沿信息生成到达时间修正信息;计算实际接收信号的相关波形的前沿参考点对应的前沿斜率;根据所述前沿斜率从所述到达时间修正信息中确定目标修正信息,并基于所述目标修正信息确定所述实际接收信号的到达时间。
本申请实施例还提供了一种到达时间的确定装置,包括:
修正信息生成模块,设置为根据不同衰落值的定位信号的理论自相关波形的前沿信息生成到达时间修正信息;前沿斜率计算模块,设置为计算实际接收信号的相关波形的前沿参考点对应的前沿斜率;到达时间确定模块,设置为根据所述前沿斜率从所述到达时间修正信息中确定目标修正信息,并基于所述目标修正信息确定所述实际接收信号的到达时间。
本申请实施例还提供了一种信号接收设备,包括:
一个或多个处理器;存储装置,用于存储一个或多个程序;当所述一个或多个程序被所述一个或多个处理器执行,使得所述一个或多个处理器实现上述的到达时间的确定方法。
本申请实施例还提供了一种计算机可读存储介质,计算机可读存储介质上存储有计算机程序,该程序被处理器执行时实现上述的到达时间的确定方法。
图1为在多径传输情况下的实际接收信号的示意图;
图2为一实施例提供的一种到达时间的确定方法的流程图;
图3为一实施例提供的另一种到达时间的确定方法的流程图;
图4为一实施例提供的一种m个第一等分线和n个定位信号的理论自相关波形的示意图;
图5为一实施例提供的一种单径信号的前沿斜率检测的示意图;
图6为一实施例提供的一种多径信号的前沿斜率检测的示意图;
图7为一实施例提供的一种到达时间的确定装置的结构示意图;
图8为一实施例提供的一种信号接收设备的硬件结构示意图。
下面结合附图和实施例对本申请进行说明。
在对无线通信网络中的设备进行定位时需要检测信号的到达时间,到达时间的检测通常是基于对信号的理论自相关三角波形的斜率检测实现,例如取首个最大相关峰作为信号的到达时间。但随着通信网络环境越来越复杂多变,例如在室内、密集城区等多径复杂的环境下,由于存在噪声和多径的影响,往往会导致信号相关波形的斜率发生畸变。
图1为在多径传输情况下的实际接收信号的示意图。图1中以信号多径传输的情况为例,其中虚线表示的是信号经过多径传输的结果,实线表示接收端实际接收到的信号波形,实际接收信号的相关波形显然已经不是理想的三角波形,因此基于斜率检测的方法来确定信号的到达时间具有非常大的误差。即便是对于单径信号,也可能由于信道质量的不稳定和其他噪声的影响或带宽限制,导致斜率检测方法误差较大,从而无法实现在复杂无线环境和带宽限制下的到达时间高精度测量。
本实施例针对在复杂多变的网络环境下基于斜率测量到达时间的精度低的情况,根据定位信号的理论自相关波形生成到达时间修正信息,根据理论的到达时间修正信息对实际接收信号的一些前沿位置的时间量进行修正,能够在多径或噪声环境下关注实际接收信号相关波形的前沿变化细节,使实际接收信号的前沿斜率的检测结果更接近理论波形,从而提高到达时间检测的精度和可靠性。
图2为一实施例提供的一种到达时间的确定方法的流程图,如图2所示,本实施例提供的方法包括步骤110-140。
在步骤110中,根据不同衰落值的定位信号的理论自相关波形的前沿信息生成到达时间修正信息。
在步骤120中,计算实际接收信号的相关波形的前沿参考点对应的前沿斜率。
在步骤130中,根据所述前沿斜率从所述到达时间修正信息中确定目标修正信息。
在步骤140中,基于所述目标修正信息确定所述实际接收信号的到达时间。
本实施例中,利用定位信号的理论自相关波形的前沿信息生成到达时间修正信息,其中,定位信号的理论自相关波形可以有多个,分别对应于不同的衰落值。例如,按照一定规则将对应于不同衰落值的定位信号的理论自相关波形划分成若干段,根据划分结果可以确定理论自相关波的前沿上的若干个参考点,根据各个参考点处对应的时间量可以生成到达时间修正信息。到达时间修正信息可以表格的形式存储,到达时间修正信息中的每一项对应于一个参考点,记录了该参考点的前沿信息,前沿信息可以包括斜率和时间量等,根据理论自相关波形生成的到达时间修正信息符合信号在理想状态下的传输结果。
由于实际接收信号的斜率已经发生畸变,在与上述各个参考点相应的位置处所对应的斜率可能不同,对应的时间量也不准确,因此通过斜率检测来确定到达时间是不准确的。在本实施例中,根据实际接收信号的前沿参考点的前沿 斜率,在到达时间修正信息中查找与前沿参考点相对应的位置处的目标修正信息,据此对实际接收信号的前沿参考点的时间量进行修正,在此基础上可以将各个前沿参考点的对应的修正后的时间量中的最早时间(也可以为根据最早的若干个时间或最早的一类时间量、通过数学统计运算得到的平均时间量等)作为到达时间,从而降低基于斜率检测实际接收信号的到达时间的误差。
在一实施例中,可以根据一定规则将定位信号的衰落值划分成若干种不同的值,得到对应于不同衰落值的定位信号。例如,将定位信号归一化,最大衰落值即为1,将衰落值划分为3种情况,以3等分衰落值为例,则定位信号的衰落值分别为1、2/3、1/3,得到三种定位信号的理论自相关波形;对于每种定位信号的理论自相关波形,又可以按照一定规则划分成若干段,从而确定前沿上的若干个参考点,根据各个参考点对应的斜率和时间量生成到达时间修正信息。而对于实际接收信号的相关波形,可以按照相同的规则划分成若干段,得到相应的若干个前沿参考点,根据每个前沿参考点的前沿斜率分别从到达时间修正信息中确定与其最接近的一项,即为该前沿参考点对应的目标修正信息。在一些实施例中,将定位信号的理论自相关波形根据模值或衰落值归一化,将实际接收信号的相关波形根据模值归一化,从而便于选取参考点,降低计算量。
本实施例的到达时间确定方法,根据定位信号的理论自相关波形生成到达时间修正信息,根据理论的到达时间修正信息对实际接收信号的前沿参考点进行修正,基于修正后的实际接收信号相关波形的数据确定到达时间,能够在多径或噪声环境下关注实际接收信号相关波形的前沿变化细节,使实际接收信号的前沿斜率的检测结果更接近理论波形,从而提高到达时间检测的精度和可靠性。
图3为一实施例提供的另一种到达时间的确定方法的流程图,如图3所示,本实施例提供的方法包括步骤210-270。
在步骤210中,将归一化定位信号的自相关波形按照衰落值n等分,得到对应于不同衰落值的n个定位信号的理论自相关波形。
在步骤220中,将归一化定位信号的自相关波形的前沿高度m等分,得到m个第一等分线。
在步骤230中,根据m个第一等分线和n个定位信号的理论自相关波形生成到达时间修正信息。
本实施例中,将定位信号按照模值归一化,即最大模值为1,将归一化定位信号的自相关波形按照衰落值n等分衰是指:将归一化定位信号的自相关波形分为n种情况,依次为:自相关函数最大模值为1的情况,自相关函数最大模 值为(n-1)/n的情况,…,以及自相关函数最大模值为1/n的情况,共有n个对应于不同衰落值的定位信号。此外,将归一化定位信号的自相关波形按照前沿高度从0到1进行m等分,得到m个第一等分线,每份的高度都为1/m。
图4为一实施例提供的一种m个第一等分线和n个定位信号的理论自相关波形的示意图。如图4所示,m个第一等分线对应的前沿高度从下到上依次为1/m,2/m,…,m/m;n种定位信号的理论自相关波形对应的衰落值从上到下依次为n/n,(n-1)/n,…,1/n。将第i(i=1,2,...,m)个第一等分线与第j(j=1,2,...,n)个衰落值的自相关波形在前沿的交点对应的时间量记为T
i,j,将最大衰落值对应的时间量记为T
max。如图4所示,m个第一等分线和n种定位信号的理论自相关波形的前沿具有多个交点,将这些交点作为参考点可以计算出对应的标准斜率和对应的到达时间修正值,得到到达时间修正信息,可以表格的形式存储。
在步骤240中,计算实际接收信号的相关波形的前沿参考点对应的前沿斜率。
在本实施例中,对于实际接收信号,选取一些前沿参考点,例如,通过按照模值对实际接收信号的相关波形进行m等分得到在前沿上的交点,计算这些交点的前沿斜率。对实际接收信号选取前沿参考点的规则与对定位信号的理论自相关波形选取参考点的规则一致,使得实际接收信号的修正更接近理论自相关波形,修正信息与实际接收信号的匹配度更高,提高到达时间检测精度。
在步骤250中,根据各前沿斜率在到达时间修正信息中查找目标修正信息,目标修正信息包括各前沿斜率对应的标准斜率以及各标准斜率对应的到达时间修正值。
到达时间修正信息中存储了多项标准斜率和对应的到达时间修正值,根据实际接收波形的前沿斜率,可以在到达时间修正信息中查找最接近的一项标准斜率,并读取对应的到达时间修正值。以对实际接收信号的相关波形进行m等分为例,前沿参考点的个数为m,前沿斜率的个数为m,分别为k
r(r=1,2,...,m),则查找到的目标修正信息也为m项,分别是与k
r最接近的标准斜率和到达时间修正值
,利用m个到达时间修正值可以分别对m个前沿参考点所在的时间量进行修正。
在步骤260中,根据各到达时间修正值计算所述各前沿斜率对应的候选到达时间。
在步骤270中,根据各候选到达时间确定实际接收信号的到达时间。
本实施例中,对m个的前沿参考点和查找到的m个到达时间修正值,依次求得m个修正后的到达时间,即候选到达时间,对候选到达时间建立聚类、求均值等,从而可以将时间最早(时间量取值最小)的聚类对应的候选到达时间作为实际接收信号的到达时间。
在一实施例中,归一化定位信号的自相关波形为根据模值归一化的自相关波形;n个定位信号的理论自相关波形的最大模值的最大取值为1,最小取值为1/n;m和n分别与到达时间修正精度呈负相关。
本实施例中,根据到达时间测量的精度(到达时间测量最小误差)要求,对归一化定位信号的理论自相关波形按照前沿高度m等分并按照衰落值n等分,m越大,则精度越高,达到时间测量最小误差越小;n越大,则精度越高,达到时间测量最小误差越小,从而全面细致地考虑前沿上各位置的修正信息,提高对实际接收波形修正的精度。根据精度要求,通过仿真可以确定m和n的取值。
在一些实施例中,也可以按照其他规则划分和选取各种衰落值的理论自相关波形上的参考点,不一定是将前沿高度等分的形式,例如,可以根据幅值的统计规律在比较陡(前沿高度变化率大)或者幅值较大的前沿部分分成更多段,确定更多的参考点,以得到更密集和精准的标准斜率和到达时间修正值;而对于比较平缓(前沿高度变化率小)或者幅值较小的前沿部分可以选取较少的参考点,在一定程度上简化计算。
在一实施例中,到达时间修正信息包括标准斜率和到达时间修正值。
步骤230包括:
步骤231:计算各所述第一等分线与各所述定位信号的理论自相关波形的前沿的交点对应的标准斜率。
步骤232:根据所述归一化定位信号的自相关波形的最大模值对应的时间量与各所述交点对应的时间量之间的差值确定各所述标准斜率对应的到达时间修正值。
本实施例中,到达时间修正信息包括标准斜率和到达时间修正值,第i(i=1,2,...,m)个第一等分线与第j(j=1,2,...,n)个衰落值的定位信号的理论自相关波形的交点处对应的标准斜率记为k
i,j,对应的到达时间修正值记为α
i,j,则生成到达时间修正信息的依据如下:
 i∈(1,m],j∈(1,n];α
i,j=T
max-T
i,j,i∈(1,m],j∈(1,n]。其中,k
i,j为表项中的标准斜率,α
i,j为到达时间修正值,T
max为理论自相关波形的最大模值对应的时间量,T
i,j为自相关函数最大模值为j/n、前沿高度为i/m的数据点对应的时间值。
 为理论自相关函数时间为T
i,j处的数据,
 为理论自相关函数时间为T
i,j+Δc处的数据,Δc为理论自相关函数波形上和T
i,j处相邻的数据点的时间差,L为计算斜率用到的相邻点范围,例如L=5。通过基于最大模值对应的时间量确定到达时间修正值,使各个交点处的时间量加上一定的修正值后更接近最大模值处,将该修正值应用于实际接收波形上,即可提高对实际接收波形修正的准确性,提高检测精度。
表1根据m个第一等分线和n个定位信号的理论自相关波形生成的到达时间修正信息

表1为根据m个第一等分线和n个定位信号的理论自相关波形生成的到达时间修正信息。如表1所示,到达时间修正信息以表格的形式存储,到达时间修正表可以是一个二维表格,横轴为n种衰落值,纵轴为m种前沿高度,表项包括标准斜率和到达时间修正值。第i个第一等分线与第j个衰落值的定位信号的理论自相关波形对应的到达时间修正信息包括标准斜率k
i,j和到达时间修正值α
ij。
在一实施例中,步骤240包括:
步骤241:将所述实际接收信号的相关波形的前沿高度m等分,得到m个第二等分线。
步骤242:根据所述m个第二等分线和所述实际接收信号的相关波形的前沿的交点确定m个前沿参考点。
步骤243:分别计算各所述前沿参考点对应的前沿斜率。
在本实施例中,对实际接收信号的相关波形按照前沿高度m等分,得到m个第二等分线。本实施例中,对实际接收信号选取前沿参考点的规则与对定位信号的理论自相关波形选取参考点的规则一致,使得实际接收信号的修正更接近理论自相关波形,修正信息与实际接收信号的匹配度更高,提高到达时间检测精度。
为便于计算,将实际接收信号的相关波形归一化,则划分成的每一份的高 度都为1/m,每个第二等分线对应的幅值依次为1/m,2/m,……,m/m,每个第二等分线与相关波形前沿的交点都是一个前沿参考点,共有m个参考点,分别对应于m个前沿斜率。将各前沿参考点对应的前沿斜率记为k
r(r=1,2,...,m),对每个前沿参考点(利用其附近相邻点)计算前沿斜率k
r的依据如下:
 其中,
 为对应于第r个第二等分线的交点处的数据,
 为与该交点相隔时间为Δc的接收相关波形数据,T
r为该交点处对应的时间量。
在一实施例中,实际接收信号的相关波形为根据模值归一化的相关波形。
本实施例中,将实际接收信号与信号接收设备本地保存的发送序列做数学相关运算,可以得到实际接收信号的相关波形,将相关波形整体除以最大模值,可以得到归一化的自相关波形。
在一些实施例中,也可以按照其他规则选取实际接收波形的前沿参考点,不一定是将前沿高度等分的形式,例如,可以根据幅值的统计规律在比较陡(前沿高度变化率大)或者幅值较大的前沿部分分成更多段,确定更多的前沿参考点,以进行更精密的修正;而对于比较平缓(前沿高度变化率小)或者幅值较小的前沿部分可以选取较少的参考点,在一定程度上简化计算。
在一实施例中,步骤250包括:
对于各所述前沿斜率,将所述到达时间修正信息中与所述前沿斜率最接近的标准斜率作为所述前沿斜率对应的标准斜率,并读取对应的到达时间修正值。
对于每个前沿斜率记为k
r,搜索到达时间修正信息(记为Ω),得到表项中与k
r最接近的标准斜率:k
r,i,j=min(|k
i,j-k
r|),k
i,j∈Ω,对应的α
i,j即为查找到的最接近k
r的表项对应的到达时间修正值。
在一实施例中,步骤260包括:
将各所述前沿斜率对应的实际时间与对应的到达时间修正值的和值作为所述前沿斜率对应的候选到达时间。
本实施例中,实际接收信号的相关波形上的第r个第二等分线的交点处的实际时间量表示为T
r,则对应的修正后的候选到达时间可表示为TOA
r=T
r+α
i,j。
在一实施例中,步骤270包括:
步骤271:根据聚类判别门限建立各所述候选到达时间的聚类,每个聚类中包含至少一个候选到达时间。
步骤272:根据候选到达时间取值最小的聚类确定所述实际接收信号的到达 时间。
在一实施例中,在x个候选到达时间中任意两个候选到达时间之间的差值均小于或等于聚类判别门限的情况下,x个候选到达时间属于一个聚类,其中,x为大于或等于2的整数。
本实施例中,建立聚类的依据是,对于任意TOA
i和TOA
j,i,j∈[1,m],如果满足:|TOA
i-TOA
j|≤Z,则TOA
i和TOA
j属于一个聚类,其中,Z为聚类判别门限,可以通过仿真确定。Z的取值可根据到达时间测量精度要求确定。
在一实施例中,步骤272包括:
计算各所述聚类对应的候选到达时间的均值,将最小的均值作为所述实际接收信号的到达时间。
本实施例中,对各个聚类计算候选到达时间的平均值,作为该聚类的候选TOA,最小的聚类是指最小的候选TOA所在的聚类。对于所有聚类的候选TOA,取最小的候选TOA作为信号的最早到达时间。在一些实施例中,也可以将最小的候选到达时间所在的聚类作为最小的聚类,将最小的聚类对应的各候选到达时间的均值作为到达时间。
以下分别以单径信号和多径信号为例,通过实例对到达时间检测过程进行说明。
实例1:对单径信号基于前沿斜率检测确定到达时间
参数设置:基站发射的定位信号为第三代合作伙伴计划(3rd Generation Partnership Project,3GPP)标准的定位参考信号(Positioning Reference Signals,PRS),主要参数包括带宽100M,物理小区标识(Physical Cell Identifier,PCI)为1,采样周期Ts=8ns,过采样倍数为30。对于单径信号,接收端将实际接收信号与本地做相关运算,得到相关波形。
1)对定位信号进行归一化,将归一化定位信号的理论自相关波形按照前要高度10等分,按照衰落值20等分,生成到达时间修正信息。表2为生成的到达时间修正信息表,如表2所示,修正表中包括不同前沿高度和衰落值下对应的标准斜率以及对应的到达时间修正值。
表2到达时间修正信息表


2)计算实际接收信号的相关波形的前沿斜率。图5为一实施例提供的一种单径信号的前沿斜率检测的示意图。在实际接收信号为单径信号的情况下,无多径影响,其相关波形如图5所示,对其按照前沿高度进行10等分,并计算各等分线与前沿交点处的前沿斜率,前沿斜率共有10个,记为k
r(r=1,2,...,10)。
3)针对每个前沿斜率k
r分别搜索到达时间修正表,确定目标修正信息,包括找到表2中与k
r最接近的标准斜率k
r,i,j,并读取对应的到达时间修正值。例如,图5中,在前沿高度为1/m(m=10)处的前沿参考点的前沿斜率为k1,表2中与k
1最接近的标准斜率为k
1,20=0.0071,则读取对应的到达时间修正值为α
1,n=109。对每个前沿斜率k
r(r=1,2,...,10)都按照此方式进行搜索,共得到10个到达时间修正值,α
i,j(
i=1,2,...,10)分别为:{109,96,84,73,62,52,42,33,22,0}。
4)根据目标修正信息对各前沿参考点对应的时间量进行修正。图5所示的相关波形中,各前沿参考点对应的原始时间量T
r(
i=1,2,...,10)分别为:{245651,245664,245676,245687,245698,245708,245718,245727,245738,245760},则根据T
r+τ
i,j分别求得10个修正后的候选到达时间,候选到达时间分别为:{245760, 245760,245760,245760,245760,245760,245760,245760,245760,245760}。
5)对候选到达时间进行聚类,令聚类判别门限Z=5,上述的各候选到达时间之间的差距均小于5,则上述的候选到达时间均属于同一个聚类,这是由于单径信号没有受到多径传输的影响,其相关波形较接近理想状态,各候选到达时间之间的误差和波动也小。该聚类中候选到达时间的平均值为245760,即最终测得的TOA为245760,上述的时间量单位为Ts/30。
实例2:对多径信号基于前沿斜率检测确定到达时间
参数设置:基站发射的定位信号为3GPP标准的PRS信号,主要参数包括带宽100M,物理小区标识(Physical Cell Identifier,PCI)为1,采样周期Ts=8ns,过采样倍数为30。本实例中,构造两条径的多径信道,第一条径衰减0.5,第二条径无衰减,延迟100(Ts/30)。
1)对定位信号进行归一化,将归一化定位信号的理论自相关波形按照前要高度10等分,按照衰落值20等分,生成到达时间修正信息,参考表2。
2)计算实际接收信号的相关波形的前沿斜率。图6为一实施例提供的一种多径信号的前沿斜率检测的示意图。在实际接收信号为多径信号的情况下,和本地信号做相关运算后得到的相关波形如图6所示,对其按照前沿高度进行10等分,并计算各等分线与前沿交点处的前沿斜率,前沿斜率共有10个,记为k
r(r=1,2,...,10)。
3)针对每个前沿斜率k
r分别搜索到达时间修正表,确定目标修正信息,包括找到表2中与k
r最接近的标准斜率k
i,j,并读取对应的到达时间修正值,共得到10个到达时间修正值,α
i,j(
i=1,2,...,10)分别为:{94,77,66,33,41,52,42,33,22,0}。
4)根据目标修正信息对各前沿参考点对应的时间量进行修正。图6所示的相关波形中,各前沿参考点对应的原始时间量T
r(r=1,2,...,10)分别为:{245664,245686,245705,245723,245803,245814,245824,245833,245843,245864},则根据T
r+τ
i,j分别求得10个修正后的候选到达时间,候选到达时间分别为:{245758,245763,245771,245756,245844,245866,45866,245866,245865,245864}。
5)对候选到达时间进行聚类,令聚类判别门限Z=5,得到最小的聚类为{245756,245758},该聚类中候选到达时间的平均值为245757,即最终测得的TOA为245757,上述的时间量单位为Ts/30。
上述实施例的到达时间确定方法,通过对定位信号的理论自相关波形以及实际接收信号的相关波形归一化并进行等分,确定参考点,使理论自相关波形以及实际接收信号的相关波形的相应位置对应起来,利用理论的标准斜率和到 达时间修正值修正实际接收信号的前沿参考点时间量,在此基础上,根据最小聚类确定到达时间,能够显著降低带宽信号对斜率检测的影响,够细化多径环境自相关信号前沿的变化细节,提高检测精度。
本申请实施例还提供一种到达时间的确定装置。图7为一实施例提供的一种到达时间的确定装置的结构示意图。如图7所示,所述到达时间的确定装置包括:修正信息生成模块310、前沿斜率计算模块320和到达时间确定模块330。
修正信息生成模块310,设置为根据不同衰落值的定位信号的理论自相关波形的前沿信息生成到达时间修正信息;前沿斜率计算模块320,设置为计算实际接收信号的相关波形的前沿参考点对应的前沿斜率;到达时间确定模块330,设置为根据所述前沿斜率从所述到达时间修正信息中确定目标修正信息,并基于所述目标修正信息确定所述实际接收信号的到达时间。
本实施例的到达时间的确定装置,根据定位信号的理论自相关波形生成到达时间修正信息,根据理论的到达时间修正信息对实际接收信号的一些前沿位置的时间量进行修正,能够在多径或噪声环境下关注实际接收信号相关波形的前沿变化细节,使实际接收信号的前沿斜率的检测结果更接近理论波形,从而提高到达时间检测的精度和可靠性。
在一实施例中,修正信息生成模块310,包括:
第一等分单元,设置为将归一化定位信号的自相关波形按照衰落值n等分,得到对应于不同衰落值的n个定位信号的理论自相关波形;第二等分单元,设置为将所述归一化定位信号的自相关波形的前沿高度m等分,得到m个第一等分线;修正单元,设置为根据所述m个第一等分线和所述n个定位信号的理论自相关波形生成所述到达时间修正信息;其中,m和n均为大于2的整数。
在一实施例中,所述到达时间修正信息包括标准斜率和到达时间修正值;所述修正单元,包括:
第一计算子单元,设置为计算各所述第一等分线与各所述定位信号的理论自相关波形的前沿的交点对应的标准斜率;第二计算子单元,设置为根据所述归一化定位信号的自相关波形的最大模值对应的时间量与各所述交点对应的时间量之间的差值确定各所述标准斜率对应的到达时间修正值。
在一实施例中,前沿斜率计算模块320,包括:
第三等分单元,设置为将所述实际接收信号的相关波形的前沿高度m等分,得到m个第二等分线;参考点确定单元,设置为根据所述m个第二等分线和所述实际接收信号的相关波形的前沿的交点确定m个前沿参考点;斜率计算模块, 设置为分别计算各所述前沿参考点对应的前沿斜率。
在一实施例中,到达时间确定模块330,包括:
查找单元,设置为根据各所述前沿斜率在所述到达时间修正信息中查找目标修正信息,所述目标修正信息包括各所述前沿斜率对应的标准斜率以及各所述标准斜率对应的到达时间修正值;候选时间计算单元,设置为根据各所述到达时间修正值计算所述各所述前沿斜率对应的候选到达时间;到达时间确定单元,设置为根据各所述候选到达时间确定所述实际接收信号的到达时间。
在一实施例中,所述查找单元,设置为:
对于各所述前沿斜率,将所述到达时间修正信息中与所述前沿斜率最接近的标准斜率作为所述前沿斜率对应的标准斜率,并读取对应的到达时间修正值。
在一实施例中,所述候选时间计算单元,设置为:
将各所述前沿斜率对应的实际时间与对应的到达时间修正值的和值作为所述前沿斜率对应的候选到达时间。
在一实施例中,所述到达时间确定单元,包括:
聚类子单元,设置为根据聚类判别门限建立各所述候选到达时间的聚类,每个聚类中包含至少一个候选到达时间;时间确定子单元,设置为根据候选到达时间取值最小的聚类确定所述实际接收信号的到达时间。
在一实施例中,所述时间确定子单元,设置为:
将所述候选到达时间取值最小的聚类中的各所述候选到达时间的均值作为所述实际接收信号的到达时间。
在一实施例中,在x个候选到达时间中任意两个候选到达时间之间的差值均小于或等于所述聚类判别门限的情况下,所述x个候选到达时间属于一个聚类,其中,所述x为大于或等于2的整数。
在一实施例中,所述归一化定位信号的自相关波形为根据模值归一化的自相关波形;所述n个定位信号的理论自相关波形的最大模值的最大取值为1,最小取值为1/n;m和n分别与到达时间修正精度呈负相关。
在一实施例中,所述实际接收信号的相关波形为根据模值归一化的相关波形。
本实施例提出的到达时间的确定装置与上述实施例提出的到达时间的确定方法属于同一申请构思,未在本实施例中详尽描述的技术细节可参见上述任意实施例,并且本实施例具备与执行到达时间的确定方法相同的有益效果。
本申请实施例还提供一种信号接收设备。所述到达时间的确定方法可以由到达时间的确定装置执行,该到达时间的确定装置可以通过软件和/或硬件的方式实现,并集成在所述信号接收设备中。
图8为一实施例提供的一种信号接收设备的硬件结构示意图。如图8所示,本实施例提供的一种信号接收设备,包括:处理器410和存储装置420。该信号接收设备中的处理器可以是一个或多个,图8中以一个处理器410为例,所述设备中的处理器410和存储装置420可以通过总线或其他方式连接,图8中以通过总线连接为例。
所述一个或多个程序被所述一个或多个处理器410执行,使得所述一个或多个处理器实现上述任一实施例所述的到达时间的确定方法。
该信号接收设备中的存储装置420作为一种计算机可读存储介质,可用于存储一个或多个程序,所述程序可以是软件程序、计算机可执行程序以及模块,如本申请实施例中到达时间的确定方法对应的程序指令/模块(例如,附图7所示的到达时间的确定装置中的模块,包括:修正信息生成模块310、前沿斜率计算模块320和到达时间确定模块330)。处理器410通过运行存储在存储装置420中的软件程序、指令以及模块,从而执行信号接收设备的各种功能应用以及数据处理,即实现上述方法实施例中的到达时间的确定方法。
存储装置420主要包括存储程序区和存储数据区,其中,存储程序区可存储操作系统、至少一个功能所需的应用程序;存储数据区可存储根据设备的使用所创建的数据等(如上述实施例中的到达时间修正信息、前沿斜率等)。此外,存储装置420可以包括高速随机存取存储器,还可以包括非易失性存储器,例如至少一个磁盘存储器件、闪存器件、或其他非易失性固态存储器件。在一些实例中,存储装置420可包括相对于处理器410远程设置的存储器,这些远程存储器可以通过网络连接至信号接收设备。上述网络的实例包括但不限于互联网、企业内部网、局域网、移动通信网及其组合。
并且,当上述信号接收设备中所包括一个或者多个程序被所述一个或者多个处理器410执行时,实现如下操作:根据不同衰落值的定位信号的理论自相关波形的前沿信息生成到达时间修正信息;计算实际接收信号的相关波形的前沿参考点对应的前沿斜率;根据所述前沿斜率从所述到达时间修正信息中确定目标修正信息,并基于所述目标修正信息确定所述实际接收信号的到达时间。
本实施例提出的信号接收设备与上述实施例提出的到达时间的确定方法属于同一申请构思,未在本实施例中详尽描述的技术细节可参见上述任意实施例, 并且本实施例具备与执行到达时间的确定方法相同的有益效果。
本申请实施例还提供一种包含计算机可执行指令的存储介质,计算机可执行指令在由计算机处理器执行时用于执行一种到达时间的确定方法,该方法包括:根据不同衰落值的定位信号的理论自相关波形的前沿信息生成到达时间修正信息;计算实际接收信号的相关波形的前沿参考点对应的前沿斜率;根据所述前沿斜率从所述到达时间修正信息中确定目标修正信息,并基于所述目标修正信息确定所述实际接收信号的到达时间。
通过以上关于实施方式的描述,本申请可借助软件及通用硬件来实现,也可以通过硬件实现。基于这样的理解,本申请的技术方案可以以软件产品的形式体现出来,该计算机软件产品可以存储在计算机可读存储介质中,如计算机的软盘、只读存储器(Read-Only Memory,ROM)、随机存取存储器(Random Access Memory,RAM)、闪存(FLASH)、硬盘或光盘等,包括多个指令用以使得一台计算机设备(可以是个人计算机,服务器,或者网络设备等)执行本申请任意实施例所述的方法。
本申请附图中的任何逻辑流程的框图可以表示程序步骤,或者可以表示相互连接的逻辑电路、模块和功能,或者可以表示程序步骤与逻辑电路、模块和功能的组合。计算机程序可以存储在存储器上。存储器可以具有任何适合于本地技术环境的类型并且可以使用任何适合的数据存储技术实现,例如但不限于只读存储器(ROM)、随机访问存储器(RAM)、光存储器装置和系统(数码多功能光碟(Digital Video Disc,DVD)或光盘(Compact Disk,CD))等。计算机可读介质可以包括非瞬时性存储介质。数据处理器可以是任何适合于本地技术环境的类型,例如但不限于通用计算机、专用计算机、微处理器、数字信号处理器(Digital Signal Processing,DSP)、专用集成电路(Application Specific Integrated Circuit,ASIC)、可编程逻辑器件(Field-Programmable Gate Array,FPGA)以及基于多核处理器架构的处理器。
Claims (15)
- 一种到达时间的确定方法,包括:根据不同衰落值的定位信号的理论自相关波形的前沿信息生成到达时间修正信息;计算实际接收信号的相关波形的前沿参考点对应的前沿斜率;根据所述前沿斜率从所述到达时间修正信息中确定目标修正信息,并基于所述目标修正信息确定所述实际接收信号的到达时间。
- 根据权利要求1所述的方法,其中,所述根据不同衰落值的定位信号的理论自相关波形的前沿信息生成到达时间修正信息,包括:将归一化定位信号的自相关波形按照衰落值n等分,得到对应于不同衰落值的n个定位信号的理论自相关波形;将所述归一化定位信号的自相关波形的前沿高度m等分,得到m个第一等分线;根据所述m个第一等分线和所述n个定位信号的理论自相关波形生成所述到达时间修正信息;其中,m和n均为大于2的整数。
- 根据权利要求2所述的方法,其中,所述到达时间修正信息包括标准斜率和到达时间修正值;所述根据所述m个第一等分线和所述n个定位信号的理论自相关波形生成所述到达时间修正信息,包括:计算所述m个第一等分线与所述n个定位信号的理论自相关波形的前沿的多个交点对应的标准斜率;根据所述归一化定位信号的自相关波形的最大模值对应的时间量与每个交点对应的时间量之间的差值确定所述交点的标准斜率对应的到达时间修正值。
- 根据权利要求2所述的方法,其中,所述计算所述实际接收信号的相关波形的前沿参考点对应的前沿斜率,包括:将所述实际接收信号的相关波形的前沿高度m等分,得到m个第二等分线;根据所述m个第二等分线和所述实际接收信号的相关波形的前沿的交点确定m个前沿参考点;分别计算所述m个前沿参考点对应的前沿斜率。
- 根据权利要求4所述的方法,其中,所述根据所述前沿斜率从所述到达 时间修正信息中确定目标修正信息,并基于所述目标修正信息确定所述实际接收信号的到达时间,包括:根据每个前沿斜率在所述到达时间修正信息中查找目标修正信息,所述目标修正信息包括所述前沿斜率对应的标准斜率以及所述标准斜率对应的到达时间修正值;根据所述到达时间修正值计算所述前沿斜率对应的候选到达时间;根据m个候选到达时间确定所述实际接收信号的到达时间。
- 根据权利要求5所述的方法,其中,所述根据每个前沿斜率在所述到达时间修正信息中查找目标修正信息,包括:对于每个前沿斜率,将所述到达时间修正信息中与所述前沿斜率最接近的标准斜率作为所述前沿斜率对应的标准斜率,并读取所述最接近的标准斜率对应的到达时间修正值。
- 根据权利要求5所述的方法,其中,所述根据所述到达时间修正值计算所述前沿斜率对应的候选到达时间,包括:将所述前沿斜率对应的实际时间与对应的到达时间修正值的和值作为所述前沿斜率对应的候选到达时间。
- 根据权利要求5所述的方法,其中,所述根据m个候选到达时间确定所述实际接收信号的到达时间,包括:根据聚类判别门限建立所述m个候选到达时间的聚类,每个聚类中包含至少一个候选到达时间;根据候选到达时间取值最小的聚类确定所述实际接收信号的到达时间。
- 根据权利要求8所述的方法,其中,所述根据候选到达时间取值最小的聚类确定所述实际接收信号的到达时间,包括:计算每个聚类对应的候选到达时间的均值,将最小的均值作为所述实际接收信号的到达时间。
- 根据权利要求8所述的方法,其中,在x个候选到达时间中每两个候选到达时间之间的差值小于或等于所述聚类判别门限的情况下,所述x个候选到达时间属于一个聚类,其中,x为大于或等于2的整数。
- 根据权利要求2所述的方法,其中,所述归一化定位信号的自相关波形为根据模值归一化的自相关波形;每个定位信号的理论自相关波形的最大模值的最大取值为1,最小取值为 1/n;m和n分别与到达时间修正精度呈负相关。
- 根据权利要求1所述的方法,其中,所述实际接收信号的相关波形为根据模值归一化的相关波形。
- 一种到达时间的确定装置,包括:修正信息生成模块,设置为根据不同衰落值的定位信号的理论自相关波形的前沿信息生成到达时间修正信息;前沿斜率计算模块,设置为计算实际接收信号的相关波形的前沿参考点对应的前沿斜率;到达时间确定模块,设置为根据所述前沿斜率从所述到达时间修正信息中确定目标修正信息,并基于所述目标修正信息确定所述实际接收信号的到达时间。
- 一种信号接收设备,包括:至少一个处理器;存储装置,设置为存储至少一个程序;当所述至少一个程序被所述至少一个处理器执行,使得所述至少一个处理器实现如权利要求1-12中任一项所述的到达时间的确定方法。
- 一种计算机可读存储介质,存储有计算机程序,其中,所述程序被处理器执行时实现如权利要求1-12中任一项所述的到达时间的确定方法。
Priority Applications (2)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| EP20928105.4A EP4132015A4 (en) | 2020-04-01 | 2020-12-23 | METHOD AND APPARATUS FOR DETERMINING TIME OF ARRIVAL, SIGNAL RECEIVING DEVICE AND STORAGE MEDIUM |
| US17/785,625 US12253619B2 (en) | 2020-04-01 | 2020-12-23 | Method and apparatus for determining time of arrival, signal receiving device, and storage medium |
Applications Claiming Priority (2)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| CN202010251397.7A CN111901743B (zh) | 2020-04-01 | 2020-04-01 | 到达时间的确定方法、装置、信号接收设备及存储介质 |
| CN202010251397.7 | 2020-04-01 |
Publications (1)
| Publication Number | Publication Date |
|---|---|
| WO2021196764A1 true WO2021196764A1 (zh) | 2021-10-07 |
Family
ID=73206213
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| PCT/CN2020/138462 Ceased WO2021196764A1 (zh) | 2020-04-01 | 2020-12-23 | 到达时间的确定方法、装置、信号接收设备及存储介质 |
Country Status (4)
| Country | Link |
|---|---|
| US (1) | US12253619B2 (zh) |
| EP (1) | EP4132015A4 (zh) |
| CN (1) | CN111901743B (zh) |
| WO (1) | WO2021196764A1 (zh) |
Families Citing this family (3)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN111901743B (zh) * | 2020-04-01 | 2025-07-29 | 中兴通讯股份有限公司 | 到达时间的确定方法、装置、信号接收设备及存储介质 |
| CN112379335B (zh) * | 2020-11-13 | 2024-07-26 | 清源智翔(重庆)科技有限公司 | 一种基于幅度差分信息的到达时间测量方法 |
| CN113777987B (zh) * | 2021-09-13 | 2024-08-30 | 天津津航计算技术研究所 | 一种支持波形修正的自适应离散信号采集装置 |
Citations (6)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN104237740A (zh) * | 2014-09-23 | 2014-12-24 | 国家电网公司 | 架空线-电缆混合线路分布式故障测距方法 |
| US20150094086A1 (en) * | 2012-05-07 | 2015-04-02 | Commonwealth Scientific And Industrial Research Organisation | Wireless positioning |
| WO2018208730A1 (en) * | 2017-05-10 | 2018-11-15 | Nokia Of America Corporation | System and method for wireless time-of-arrival localization |
| CN110346756A (zh) * | 2019-07-10 | 2019-10-18 | 四川中电昆辰科技有限公司 | 一种信号包络检测装置及方法及其到达时间修正方法 |
| CN110346755A (zh) * | 2019-07-10 | 2019-10-18 | 四川中电昆辰科技有限公司 | 一种信号幅值检测装置及方法及其到达时间修正方法 |
| CN111901743A (zh) * | 2020-04-01 | 2020-11-06 | 中兴通讯股份有限公司 | 到达时间的确定方法、装置、信号接收设备及存储介质 |
Family Cites Families (9)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| US5266953A (en) * | 1991-08-01 | 1993-11-30 | Allied-Signal Inc. | Adaptive fixed-threshold pulse time-of-arrival detection apparatus for precision distance measuring equipment applications |
| GB0327794D0 (en) * | 2003-11-29 | 2003-12-31 | Koninkl Philips Electronics Nv | Positioning method and apparatus |
| US7574221B2 (en) | 2006-08-03 | 2009-08-11 | Ntt Docomo, Inc. | Method for estimating jointly time-of-arrival of signals and terminal location |
| DE602008004859D1 (de) * | 2007-07-30 | 2011-03-24 | Core Logic Inc | Positionsmessung |
| US7667649B2 (en) * | 2007-12-10 | 2010-02-23 | Trueposition, Inc. | Detection of time of arrival of CDMA signals in a wireless location system |
| US8249622B2 (en) | 2008-11-26 | 2012-08-21 | Andrew, Llc | System and method for multiple range estimation location |
| CN104219761A (zh) * | 2014-10-09 | 2014-12-17 | 中国石油大学(华东) | 一种基于最大斜率的超宽带无线定位方法 |
| CN107015250B (zh) * | 2017-04-19 | 2019-09-06 | 北京邮电大学 | 一种基于线性回归的多径抑制方法及装置 |
| US10880678B1 (en) * | 2018-08-07 | 2020-12-29 | Nestwave Sas | Indoor and outdoor geolocation and time of arrival estimation |
-
2020
- 2020-04-01 CN CN202010251397.7A patent/CN111901743B/zh active Active
- 2020-12-23 WO PCT/CN2020/138462 patent/WO2021196764A1/zh not_active Ceased
- 2020-12-23 US US17/785,625 patent/US12253619B2/en active Active
- 2020-12-23 EP EP20928105.4A patent/EP4132015A4/en active Pending
Patent Citations (6)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| US20150094086A1 (en) * | 2012-05-07 | 2015-04-02 | Commonwealth Scientific And Industrial Research Organisation | Wireless positioning |
| CN104237740A (zh) * | 2014-09-23 | 2014-12-24 | 国家电网公司 | 架空线-电缆混合线路分布式故障测距方法 |
| WO2018208730A1 (en) * | 2017-05-10 | 2018-11-15 | Nokia Of America Corporation | System and method for wireless time-of-arrival localization |
| CN110346756A (zh) * | 2019-07-10 | 2019-10-18 | 四川中电昆辰科技有限公司 | 一种信号包络检测装置及方法及其到达时间修正方法 |
| CN110346755A (zh) * | 2019-07-10 | 2019-10-18 | 四川中电昆辰科技有限公司 | 一种信号幅值检测装置及方法及其到达时间修正方法 |
| CN111901743A (zh) * | 2020-04-01 | 2020-11-06 | 中兴通讯股份有限公司 | 到达时间的确定方法、装置、信号接收设备及存储介质 |
Non-Patent Citations (1)
| Title |
|---|
| See also references of EP4132015A4 * |
Also Published As
| Publication number | Publication date |
|---|---|
| EP4132015A1 (en) | 2023-02-08 |
| US12253619B2 (en) | 2025-03-18 |
| CN111901743B (zh) | 2025-07-29 |
| EP4132015A4 (en) | 2024-05-08 |
| US20230029291A1 (en) | 2023-01-26 |
| CN111901743A (zh) | 2020-11-06 |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| KR102416604B1 (ko) | 무선통신 시스템의 정밀 측위 방법 및 장치 | |
| US11641612B2 (en) | Path discrimination | |
| CN103323812B (zh) | 用于定位的系统和方法 | |
| US9681267B2 (en) | Positioning techniques for narrowband wireless signals under dense multipath conditions | |
| CN110351658B (zh) | 一种基于卷积神经网络的室内定位方法 | |
| US12253619B2 (en) | Method and apparatus for determining time of arrival, signal receiving device, and storage medium | |
| Xiong et al. | Synchronicity: Pushing the envelope of fine-grained localization with distributed mimo | |
| CN111123312A (zh) | 一种高动态低信噪比环境下的卫星弱信号捕获方法及系统 | |
| CN111770528B (zh) | 基于信道参数萃取方法的视距与非视距识别方法及装置 | |
| CN105044699B (zh) | 基于Radon‑Fourier变换的雷达点迹凝聚方法 | |
| WO2024140841A1 (zh) | 感知方法及装置 | |
| Kwon et al. | Passive localization: Large size sensor network localization based on environmental events | |
| WO2023131192A1 (zh) | 定位方法、装置、基站、定位服务器及可读存储介质 | |
| CN103595682A (zh) | 一种用于ofdm的帧同步方法、装置及接收机 | |
| CN107015250A (zh) | 一种基于线性回归的多径抑制方法及装置 | |
| WO2021196765A1 (zh) | 到达时间确定方法、装置、终端设备及存储介质 | |
| CN117354710A (zh) | 载波相位相关测量方法、装置、设备及可读存储介质 | |
| CN113866710A (zh) | 一种基于fpga的多通道测向接收机高精度相位差测量方法 | |
| WO2018171151A1 (zh) | 时间差确定的方法和装置 | |
| CN116299166B (zh) | 一种用于chirp信号的低复杂度融合测距方法 | |
| CN108989261A (zh) | 一种通信系统的定时同步方法、装置及相关设备 | |
| CN115480209B (zh) | 一种多天线uwb的nlos识别方法 | |
| CN119698695A (zh) | 定位方法、电子设备、计算机可读存储介质及芯片系统 | |
| CN121357679B (zh) | 面向时频混叠信号的toa估计方法、装置、设备和介质 | |
| Zhang et al. | CSI-based calibration free localization with rotating antenna for coal mine |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| 121 | Ep: the epo has been informed by wipo that ep was designated in this application |
Ref document number: 20928105 Country of ref document: EP Kind code of ref document: A1 |
|
| NENP | Non-entry into the national phase |
Ref country code: DE |
|
| ENP | Entry into the national phase |
Ref document number: 2020928105 Country of ref document: EP Effective date: 20221102 |
|
| WWG | Wipo information: grant in national office |
Ref document number: 17785625 Country of ref document: US |