WO2022001248A1 - 风力发电机组及其避转速控制方法、装置 - Google Patents
风力发电机组及其避转速控制方法、装置 Download PDFInfo
- Publication number
- WO2022001248A1 WO2022001248A1 PCT/CN2021/083977 CN2021083977W WO2022001248A1 WO 2022001248 A1 WO2022001248 A1 WO 2022001248A1 CN 2021083977 W CN2021083977 W CN 2021083977W WO 2022001248 A1 WO2022001248 A1 WO 2022001248A1
- Authority
- WO
- WIPO (PCT)
- Prior art keywords
- speed
- avoidance
- interval
- rotational speed
- preset
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Ceased
Links
Images


Classifications
-
- F—MECHANICAL ENGINEERING; LIGHTING; HEATING; WEAPONS; BLASTING
- F03—MACHINES OR ENGINES FOR LIQUIDS; WIND, SPRING, OR WEIGHT MOTORS; PRODUCING MECHANICAL POWER OR A REACTIVE PROPULSIVE THRUST, NOT OTHERWISE PROVIDED FOR
- F03D—WIND MOTORS
- F03D7/00—Controlling wind motors
- F03D7/02—Controlling wind motors the wind motors having rotation axis substantially parallel to the air flow entering the rotor
- F03D7/0276—Controlling wind motors the wind motors having rotation axis substantially parallel to the air flow entering the rotor controlling rotor speed, e.g. variable speed
-
- F—MECHANICAL ENGINEERING; LIGHTING; HEATING; WEAPONS; BLASTING
- F03—MACHINES OR ENGINES FOR LIQUIDS; WIND, SPRING, OR WEIGHT MOTORS; PRODUCING MECHANICAL POWER OR A REACTIVE PROPULSIVE THRUST, NOT OTHERWISE PROVIDED FOR
- F03D—WIND MOTORS
- F03D7/00—Controlling wind motors
-
- F—MECHANICAL ENGINEERING; LIGHTING; HEATING; WEAPONS; BLASTING
- F03—MACHINES OR ENGINES FOR LIQUIDS; WIND, SPRING, OR WEIGHT MOTORS; PRODUCING MECHANICAL POWER OR A REACTIVE PROPULSIVE THRUST, NOT OTHERWISE PROVIDED FOR
- F03D—WIND MOTORS
- F03D7/00—Controlling wind motors
- F03D7/02—Controlling wind motors the wind motors having rotation axis substantially parallel to the air flow entering the rotor
- F03D7/0296—Controlling wind motors the wind motors having rotation axis substantially parallel to the air flow entering the rotor to prevent, counteract or reduce noise emissions
-
- F—MECHANICAL ENGINEERING; LIGHTING; HEATING; WEAPONS; BLASTING
- F03—MACHINES OR ENGINES FOR LIQUIDS; WIND, SPRING, OR WEIGHT MOTORS; PRODUCING MECHANICAL POWER OR A REACTIVE PROPULSIVE THRUST, NOT OTHERWISE PROVIDED FOR
- F03D—WIND MOTORS
- F03D7/00—Controlling wind motors
- F03D7/02—Controlling wind motors the wind motors having rotation axis substantially parallel to the air flow entering the rotor
- F03D7/0272—Controlling wind motors the wind motors having rotation axis substantially parallel to the air flow entering the rotor by measures acting on the electrical generator
-
- F—MECHANICAL ENGINEERING; LIGHTING; HEATING; WEAPONS; BLASTING
- F03—MACHINES OR ENGINES FOR LIQUIDS; WIND, SPRING, OR WEIGHT MOTORS; PRODUCING MECHANICAL POWER OR A REACTIVE PROPULSIVE THRUST, NOT OTHERWISE PROVIDED FOR
- F03D—WIND MOTORS
- F03D7/00—Controlling wind motors
- F03D7/02—Controlling wind motors the wind motors having rotation axis substantially parallel to the air flow entering the rotor
- F03D7/0298—Controlling wind motors the wind motors having rotation axis substantially parallel to the air flow entering the rotor to prevent, counteract or reduce vibrations
-
- F—MECHANICAL ENGINEERING; LIGHTING; HEATING; WEAPONS; BLASTING
- F05—INDEXING SCHEMES RELATING TO ENGINES OR PUMPS IN VARIOUS SUBCLASSES OF CLASSES F01-F04
- F05B—INDEXING SCHEME RELATING TO WIND, SPRING, WEIGHT, INERTIA OR LIKE MOTORS, TO MACHINES OR ENGINES FOR LIQUIDS COVERED BY SUBCLASSES F03B, F03D AND F03G
- F05B2260/00—Function
- F05B2260/96—Preventing, counteracting or reducing vibration or noise
-
- F—MECHANICAL ENGINEERING; LIGHTING; HEATING; WEAPONS; BLASTING
- F05—INDEXING SCHEMES RELATING TO ENGINES OR PUMPS IN VARIOUS SUBCLASSES OF CLASSES F01-F04
- F05B—INDEXING SCHEME RELATING TO WIND, SPRING, WEIGHT, INERTIA OR LIKE MOTORS, TO MACHINES OR ENGINES FOR LIQUIDS COVERED BY SUBCLASSES F03B, F03D AND F03G
- F05B2270/00—Control
- F05B2270/30—Control parameters, e.g. input parameters
- F05B2270/327—Rotor or generator speeds
-
- Y—GENERAL TAGGING OF NEW TECHNOLOGICAL DEVELOPMENTS; GENERAL TAGGING OF CROSS-SECTIONAL TECHNOLOGIES SPANNING OVER SEVERAL SECTIONS OF THE IPC; TECHNICAL SUBJECTS COVERED BY FORMER USPC CROSS-REFERENCE ART COLLECTIONS [XRACs] AND DIGESTS
- Y02—TECHNOLOGIES OR APPLICATIONS FOR MITIGATION OR ADAPTATION AGAINST CLIMATE CHANGE
- Y02E—REDUCTION OF GREENHOUSE GAS [GHG] EMISSIONS, RELATED TO ENERGY GENERATION, TRANSMISSION OR DISTRIBUTION
- Y02E10/00—Energy generation through renewable energy sources
- Y02E10/70—Wind energy
- Y02E10/72—Wind turbines with rotation axis in wind direction
Definitions
- the present disclosure generally relates to the technical field of wind power generation, and more particularly, to a wind turbine generator set and a method and device for avoiding rotational speed control thereof.
- avoidance speed control As the capacity of wind turbines increases, wind turbines equipped with high-flexible towers have gradually become a trend due to their high power generation performance and low cost. However, due to the low natural frequency of the high-flexible tower itself, the frequency doubled component in the operating speed of the wind turbine will overlap with the natural frequency of the high-flexible tower. In the conventional design, in order to avoid resonance between the unit and the first-order frequency of the tower at the minimum speed, the value of the minimum speed of the generator rotor is limited. This type of speed control method is called avoidance speed control.
- the tower resonance can be avoided by increasing the avoidance speed range while selecting a smaller minimum speed value.
- the rotation speed avoidance interval represents the rotation speed interval of the generator rotor that may adopt the rotation speed avoidance control method.
- An exemplary embodiment of the present disclosure is to provide a wind turbine generator set and a rotational speed avoidance control method and device thereof, which can recognize that the wind turbine generator set repeatedly passes through the rotation speed avoidance interval, and avoid the wind turbine generator set by adjusting the parameters of the rotational speed avoidance control function of the wind turbine generator set. Repeatedly pass through the abnormal situation in the avoidance speed range.
- a rotational speed avoidance control method for a wind turbine comprising: identifying whether the wind turbine repeatedly passes the rotational speed avoidance interval according to statistical information that the rotational speed of the generator is in the avoidance interval; When it is determined that the wind turbine repeatedly passes through the avoidance speed interval, the speed avoidance control parameters of the wind turbine are adjusted according to the statistical information that the speed is in the avoidance speed interval.
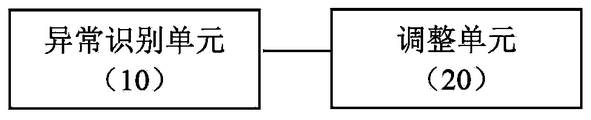
- a rotational speed avoidance control device for a wind turbine, the device comprising: an abnormality identification unit for identifying whether the wind turbine is Repeatedly passing through the avoidance speed interval; the adjustment unit, when it is determined that the wind turbine repeatedly passes the avoidance speed interval, adjusts the avoidance speed control parameters of the wind turbine according to the statistical information that the speed is in the avoidance speed interval.
- a wind power generator set including: a generator including a stator and a rotor mechanically connected with the impeller; a converter electrically coupled to the stator windings; a data acquisition module , is configured to collect the rotational speed of the generator rotor; the controller is configured to set the electromagnetic torque parameter of the converter to control the rotational speed of the generator, and the controller executes the above-mentioned rotational speed avoidance control method.
- a wind power generator set including: a generator including a stator and a rotor mechanically connected with the impeller; a converter electrically coupled to the stator windings; a data acquisition module , is configured to collect the rotational speed of the generator rotor; the controller is configured to set the electromagnetic torque parameter of the converter to control the rotational speed of the generator, and the controller includes the above-mentioned rotational speed control device.
- a computer-readable storage medium storing a computer program
- the above-mentioned method for controlling the rotational speed of a wind turbine generator is implemented.
- the generator rotation speed repeatedly passes through the rotation speed avoidance interval, and to avoid frequent entry of the generator rotation speed by adjusting the parameters of the rotation speed avoidance control function of the wind turbine. Or often in the avoidance speed range, resulting in abnormal resonance of the unit, overloading of the load, etc., to ensure the safety and reliability of the unit operation.
- FIG. 1 shows a flowchart of a method for avoiding rotational speed of a wind turbine according to an exemplary embodiment of the present disclosure
- FIG. 2 shows a schematic structural diagram of a wind turbine according to an exemplary embodiment of the present disclosure
- FIG. 3 shows a schematic diagram of avoidance speed control according to an exemplary embodiment of the present disclosure
- FIG. 4 shows a flowchart of a method for determining the ratio of rotation speed avoidance duration corresponding to each time interval in a historical operating period according to an exemplary embodiment of the present disclosure
- FIG. 5 shows an example in which the unit speed repeatedly enters the avoidance speed range according to an exemplary embodiment of the present disclosure
- FIG. 6 shows a distribution diagram of the proportion of rotation speed avoidance duration according to an exemplary embodiment of the present disclosure
- FIG. 7 shows a block diagram of a rotational speed avoidance control device for a wind turbine according to an exemplary embodiment of the present disclosure.
- FIG. 1 shows a flowchart of a method for avoiding rotational speed of a wind turbine according to an exemplary embodiment of the present disclosure.
- the method can be implemented by a computer program.
- the method may be performed offline or online.
- the method may be performed by a controller of a wind farm or a controller of a wind turbine (eg, a master controller).
- step S10 according to statistical information that the rotational speed of the generator is in the rotational speed avoidance interval, it is identified whether the wind turbine repeatedly passes through the rotational speed avoidance interval.
- the rotational speed of the generator may be the rotational speed of the generator rotor.
- the statistical information that the rotational speed of the generator rotor is in the rotational speed avoidance interval may be statistical information that can be used to determine whether the rotational speed of the wind generator is often in or frequently enters the rotational speed avoidance interval.
- the statistical information that the rotational speed of the generator is in the rotational speed avoidance interval may include: the statistical duration of the rotational speed of the generator being in the rotational speed avoidance interval and/or the statistical number of times of entering the rotational speed avoidance interval.
- the rotational speed avoidance condition of the wind turbine may refer to the condition that the rotational speed of the generator enters or is in the rotational speed avoidance interval.
- the statistical information that the rotational speed of the generator rotor is in the rotational speed avoidance interval shows that the rotational speed is often in or frequently enters the rotational speed avoidance interval beyond a certain level, it may be determined that the wind turbine repeatedly passes the rotational speed avoidance interval.
- Speed avoidance/speed ride-through control is a generator speed control function/strategy, which specifically refers to the control of the electromagnetic torque of the wind turbine converter and the generator speed, so that the wind turbine can quickly pass a certain speed during the power generation process.
- Speed range ie, avoid speed range
- the rotation speed avoidance interval mentioned in the present disclosure may be set for consideration of resonance, load reduction or other conditions, which is not limited in the present disclosure.
- the wind turbine captures wind energy by the impeller, and the generator and the converter form an energy conversion unit, which converts the wind energy into electrical energy and transmits it to the grid.
- the generator includes a stator and a rotor mechanically connected to the impeller.
- the converter is electrically coupled and connected to the stator winding.
- the generator is a permanent magnet generator with magnets in the rotor.
- the wind turbine is a direct-drive type, the converter is a full-power converter, and the electric energy converted from wind energy is all fed into the grid.
- the controller of the wind turbine collects the wind speed and the current rotational speed of the generator and sends an electromagnetic torque control signal to the converter to control the current in the stator winding of the generator to control the rotational speed of the generator rotor.
- the unit can control the pitch angle of each blade through the pitch system, so as to limit the energy absorbed by the impeller of the wind flow, and then adjust the aerodynamic torque.
- the generator power at the same time complete conversion can be controlled electromagnetic torque T e of the generator.
- the differential speed of the generator is related to the difference between the aerodynamic torque T a and the electromagnetic torque T e , where J1 is the moment of inertia, and w is the angular velocity.
- the whole unit can adjust the aerodynamic torque T a and the electromagnetic torque T e through the pitch mechanism to realize the speed control of the unit.
- FIG. 3 shows a rotational speed-electromagnetic torque operation curve of the generator, wherein the ordinate indicates the electromagnetic torque and the abscissa indicates the rotational speed.
- the speed is between Wsync and Wrated, and (Wlow, Whigh) is the avoidance speed range, Wlow is the lower boundary value of the avoidance speed range, and Whigh is the upper boundary value of the avoidance speed range, that is, the unit cannot stay in the speed range for a long time. within this speed range.
- Tlow-max and Thigh-min correspond to the electromagnetic torque control requirements at the two rotational speeds of Wlow and Whigh.
- the rotational speed cannot continue to rise according to the rotational speed avoidance control requirement.
- the speed will be controlled at Wlow. If the wind speed increases at this time, in order to maintain the speed at Wlow, the electromagnetic torque will continue to increase until it reaches Tlow-max (that is, reaching point B). The speed of V1 rad/s increases until the speed reaches Whigh, that is, the operating state reaches the point E. If the wind speed further increases at this time, the speed will continue to increase upward; when the wind speed decreases at the point E, according to the avoidance speed control requirements , the speed cannot continue to decrease, and the speed will be controlled at Whigh at this time.
- Wlow and Whigh can be determined according to the design frequency of the unit (for example, the natural frequency of structural components including the tower), but parameters such as Tlow-max, Thigh-min, T1, T2, V1 and V2 are usually simulated by And/or human experience to set, so it is very easy to cause the unit to repeatedly pass through the avoidance speed range (Wlow, Whigh) due to external wind conditions and other reasons, which will affect the safety and life of the unit.
- the statistical information of the generator speed in the avoidance speed interval can be It includes: the statistical duration of the first preset interval in which the rotational speed of the generator is in the avoidance speed interval and/or the counted number of times of entering the first preset interval.
- the first preset interval may be: (Wlow+We1, Whigh-We2).
- the rotational speed of the generator may or may not be equal to the rotational speed of the impeller.
- the step of identifying whether the wind power generating set repeatedly passes through the rotating speed avoiding range according to the statistical time period during which the rotational speed of the generator is in the rotating speed avoiding range may include: determining, according to the operation data of the historical operating period of the wind power generating set, the The ratio of the rotation speed avoidance duration corresponding to each time interval, wherein the rotation speed avoidance duration ratio corresponding to each time interval is: the total duration of the first preset interval in which the rotation speed is in the rotation speed avoidance interval within the time interval accounts for the preset and when the total number of time intervals in which the corresponding rotation speed avoidance duration ratio exceeds the preset standard ratio in the historical operation period exceeds the first preset number, it is determined that the wind turbine repeatedly passes through the rotation speed avoidance interval, wherein , and the length of each time interval is the preset duration.
- the preset duration may be used as an interval
- the operation data of the historical operation period is divided into M groups of operation data, wherein each group of operation data includes: N data of the generators collected at N consecutive sampling time points. (that is, a total of N rotational speed values are collected once the rotational speed value is collected at each sampling time point); the ratio between the number of rotational speed values in the first preset interval among the N rotational speed values of each group and N , as the proportion of rotation speed avoidance duration corresponding to each time interval, wherein M is an integer greater than 1, and N is an integer greater than 1. It should be understood that each group corresponds to a time interval, and different groups correspond to different time intervals.
- the preset standard ratio may indicate that in the case of a normal rotation speed avoidance jump, within the preset duration, the total duration of the rotation speed in the rotation speed avoidance interval accounts for the ratio of the preset duration. Therefore, when any one of When the proportion of the rotation speed avoidance duration corresponding to the time interval exceeds this normal ratio, it can indicate that the rotation speed avoidance situation in the time interval is abnormal.
- the preset standard ratio may be determined based on at least one of the following items: the jump-up time required for the wind turbine to pass through the avoidance speed interval from a low speed to a high speed (ie, (Whigh-Wlow)/ V1), the down-jump time required to cross the avoidance speed interval from high speed to low speed (ie, (Whigh-Wlow)/V2), the preset number of times that the speed can be normally passed through the avoidance speed interval within the preset time period, and the length of the preset duration.
- the preset standard ratio may be Ks: T max *I*J/L, where T max indicates the maximum value among the jump-up duration and the jump-down duration, I indicates a margin coefficient, J indicates the preset number of times that the rotation speed avoidance interval can be normally traversed within the preset duration, and L indicates the length of the preset duration.
- the number of times of normally passing through the avoidance speed interval within the preset time period may be determined according to at least one of actual operating conditions, simulation, and human experience. For example, when the length of the preset time period is 20 minutes, the number of times that the rotation speed avoidance interval can be normally passed within the preset time period may be 10.
- a margin coefficient I is added. For example, I can take a value between 1.1 and 1.5.
- FIG. 4 shows a flowchart of a method for determining the ratio of rotation speed avoidance duration corresponding to each time interval in a historical operating period according to an exemplary embodiment of the present disclosure.
- step S101 the operation data of the historical operation period of the wind turbine is acquired, wherein the operation data includes the rotational speed value.
- step S102 with the preset duration as an interval, the operation data of the historical operation period is divided into M groups of operation data. Specifically, the historical operation period is divided every preset period of time, and the obtained The operational data for each time interval forms a set of operational data.
- Each set of operating data includes: N rotational speed values of the generator collected at consecutive N sampling time points (that is, N operating points), and the N rotational speed values are collected in the order of the corresponding sampling time points. arrangement. It should be understood that N depends on the length of the preset time period and the running data sampling period.
- the historical operation period may be the latest month, and the preset period may be a value between 10min-30min.
- step S103 it is determined whether i is less than or equal to M, where the initial value of i is 1.
- step S104 is executed to determine whether j is less than or equal to N, where the initial value of j is 1.
- step S106 is executed to determine whether the j-th rotational speed value w ij in the extracted i-th group of operating data is greater than (Wlow+We1) and less than (Whigh-We2).
- step S106 When it is determined in step S106 that w ij ⁇ (Wlow+We1), or w ij ⁇ (Whigh-We2), the process returns to step S104.
- step S109 is performed to record all Ki, that is, record K1, K2, K3, . . . , KM.
- all Ki are the ratio of the rotation speed avoidance duration corresponding to each time interval in the historical operation period.
- step S20 is executed to adjust the speed avoidance control parameters of the wind turbine according to the statistical information that the speed is in the avoidance speed interval.
- the wind power generator set can be prevented from repeatedly passing through the avoidance speed range as much as possible.
- the present disclosure takes into account the problem that the unit repeatedly passes through the rotational speed avoidance interval.
- the rotational speed avoidance interval is (7.410, 8.700).
- Figure 5 shows the situation that the unit rotational speed repeatedly enters the rotational speed avoidance interval. Lead to abnormal resonance of the unit, overloading and other problems.
- the unit Affected by the change of wind, when the wind speed increases, the unit accumulates enough energy to rapidly increase the generator speed to pass the avoidance speed range, but when the wind speed drops rapidly, the electromagnetic torque reaches the upper boundary value of the avoidance speed range (ie, Whigh) corresponding to the electromagnetic torque point, the speed of the generator is rapidly reduced to avoid the speed range, and if the wind speed changes drastically, as shown in Figure 5, it fluctuates repeatedly between 2m/s-6m/s, which will cause the speed of the generator. Frequently going back and forth within the upper and lower boundary values of the avoidance speed range, the present disclosure finds that this situation is generally caused by severe changes in external wind conditions, large turbulence, and unreasonable settings of the unit speed avoidance control parameters.
- the adjusted rotational speed avoidance control parameters may include at least one of the following items: a jump-up waiting time, a jump-down waiting time, a first electromagnetic torque, and a second electromagnetic torque, wherein the jump-up waiting time is: Before crossing the avoidance speed interval from low speed to high speed, the time that the speed needs to stay at the lower boundary value of the avoidance speed interval (ie, Wlow) and the electromagnetic torque needs to stay at the first electromagnetic torque (ie, Tlow-max) (ie, , T1); the waiting time for jumping down is: before crossing the avoidance speed interval from high speed to low speed, the speed needs to be at the upper boundary value (ie, Whigh) of the avoidance speed interval and the electromagnetic torque needs to be at the second electromagnetic torque ( That is, the time spent at Thigh-min (ie, T2).
- the avoidance speed interval is an open interval.
- the waiting time for jumping up and the waiting time for jumping down may be increased, and/or the first electromagnetic torque may be increased and the second electromagnetic torque may be decreased, so as to accumulate more stable energy To achieve the purpose of the speed jumping quickly and avoiding the speed range, so as to shorten the time that the unit stays in the speed avoidance range.
- the rotational speed avoidance control parameters of the wind turbine may be adjusted according to the distribution of the rotational speed avoidance duration corresponding to the time interval in which the corresponding rotational speed avoidance duration ratio exceeds the preset standard ratio in the historical operation period.
- the reason for the abnormal speed avoidance situation can be determined according to the distribution of the abnormal rotation speed avoidance duration ratio (that is, the rotation speed avoidance duration ratio exceeding the preset standard ratio), if the abnormal rotation speed avoidance duration ratio is based on the distribution
- the distribution of the wind turbines is determined to be caused by the drastic changes in the external wind conditions, the large turbulence, and the unreasonable setting of the avoidance speed control parameters of the unit, so the avoidance speed control parameters of the wind turbine can be adjusted accordingly.
- the avoidance of the wind turbine may be adjusted.
- the rotational speed control parameter wherein the preset wind speed segment is a wind speed segment near the wind speed segment corresponding to the avoidance rotational speed interval.
- the wind speed segment corresponding to the rotation speed avoidance interval is in which wind speed segment, and the rotation speed will enter the rotation speed avoidance interval.
- the wind speed segment near the wind speed segment corresponding to the rotational speed avoidance interval may be: a wind speed segment including the wind speed segment corresponding to the rotational speed avoidance interval, and the lower boundary value of the wind speed segment is higher than the wind speed segment corresponding to the rotational speed avoidance interval.
- the lower boundary value is smaller than the first preset value
- the upper boundary value is larger than the upper boundary value of the wind speed segment corresponding to the avoidance speed interval by the second preset value.
- the time interval corresponding to the preset wind speed segment means that the ambient wind speed value of the wind turbine is in the preset wind speed segment during the time interval.
- the rotational speed avoidance control parameters may be determined according to the distribution of the rotational speed avoidance duration ratios corresponding to the time intervals corresponding to the preset wind speed segments in the historical operation period exceeding the preset standard ratio and corresponding to the rotational speed avoidance durations. and adjust the corresponding avoidance speed control parameters based on the determined adjustment amount. It should be understood that the sum or difference between the current parameter value of the avoidance speed control parameter and the determined adjustment amount is the adjusted parameter value. It should be understood that the adjustment amount determined for different avoidance speed control parameters may be different or the same.
- the proportion of the corresponding rotation speed avoidance duration in the historical operation period exceeds the preset standard ratio and the ratio of the rotation speed avoidance duration corresponding to the time interval corresponding to the preset wind speed segment, and the distance away from the preset standard ratio is greater.
- the greater the number of large and/or far away from the preset standard ratio the greater the adjustment amount of the avoidance speed control parameter can be.
- the adjustment amount is positively correlated with the degree of distance away from the preset standard ratio and/or the number of which is far away from the preset standard ratio, and the preset condition is that the ratio exceeds the preset standard ratio and the corresponding The time intervals correspond to preset wind speed segments.
- the adjustment amount of the avoidance speed control parameter may also be related to the ambient wind condition.
- the operation data used by the method according to the exemplary embodiment of the present disclosure may be the operation data of multiple wind turbines of the same model in the wind farm.
- the speed control parameters of multiple wind turbines are adjusted uniformly. Accordingly, the method may be performed by a controller of the wind farm.
- the operation data used by the method according to the exemplary embodiment of the present disclosure may be the operation data of a single wind turbine, and by executing the method, the avoidance speed of the wind turbine can be controlled parameters can be adjusted individually.
- the method can be performed by the controller of the wind farm and also by the controller of the wind turbine.
- Fig. 6 shows the distribution of the rotation speed avoidance duration ratio Ki corresponding to different time intervals of all wind turbines of the same model of the wind farm
- the abscissa in the figure indicates the wind speed
- the ordinate indicates the value of Ki
- the preset standard ratio Ks is 0.2
- each point indicates the proportion of the rotation speed avoidance time corresponding to a wind turbine in a time interval. Therefore, the point where the rotation speed avoidance time proportion exceeds 0.2 is an abnormal point, otherwise it is a normal point.
- the point set in Figure 6 is an obvious triangular structure. The highest point is near the wind speed of 6m/s. At this time, it corresponds to the wind speed point corresponding to the avoidance speed range.
- the energy provided by the wind keeps the speed at the avoidance speed.
- the rotation speed will stay at the lower boundary value for a long time; if the wind speed is too large, the rotation speed will stay at the upper boundary value for a long time. (such as 6m/s) and encountering large turbulence, there will be a problem of repeatedly entering the avoidance speed range.
- the distribution of the proportion of rotation speed avoidance time that is, there are a large number of abnormal points where the corresponding wind speed is in the vicinity of the wind speed section corresponding to the rotation speed avoidance interval (ie, 5-7m/s), and these abnormal points are Triangular structure distribution
- the abnormal speed avoidance of the wind turbine is caused by the improper setting of the avoidance speed control parameters. Therefore, this situation can be improved by adjusting the avoidance speed control parameters of the wind turbine, and further according to The distribution of abnormal points determines the adjustment amount of the rotational speed control parameters. For example, the greater the degree of distance from the abnormal point corresponding to the 5-7m/s wind speed from Ks and the greater the number of distances from Ks, the adjustment amount of the rotational speed control parameters. bigger.
- FIG. 7 shows a block diagram of a rotational speed avoidance control device for a wind turbine according to an exemplary embodiment of the present disclosure.
- the avoidance speed control device includes: an abnormality identification unit 10 and an adjustment unit 20 .
- the abnormality identification unit 10 is configured to identify whether the wind turbine repeatedly passes through the rotational speed avoidance interval according to the statistical information that the rotational speed of the generator is in the rotational speed avoidance interval.
- the adjustment unit 20 is configured to adjust the rotational speed avoidance control parameters of the wind turbine according to statistical information that the rotational speed is in the rotational speed avoidance interval when it is determined that the wind turbine repeatedly passes the rotational speed avoidance interval.
- the statistical information that the rotational speed of the generator is in the rotational speed avoidance interval may include: the statistical duration of the rotational speed of the generator being in the rotational speed avoidance interval and/or the statistical number of times of entering the rotational speed avoidance interval.
- the abnormality identification unit 10 may determine, according to the operation data of the historical operation period of the wind turbine, the ratio of the rotation speed avoidance time period corresponding to each time interval in the historical operation period; When the total number of time intervals in which the rotation speed avoidance duration ratio exceeds the preset standard ratio exceeds the first preset number, it is determined that the wind turbine repeatedly passes through the rotation speed avoidance interval, wherein the rotation speed avoidance duration ratio corresponding to each time interval is: The ratio of the total duration of the first preset interval in which the rotation speed is in the rotation speed avoidance interval within the time interval to the preset duration, wherein the length of each time interval is the preset duration.
- the abnormality identification unit 10 may divide the operation data of the historical operation period into M groups of operation data by using the preset duration as an interval, wherein each group of operation data includes: The N rotational speed values of the generator; and the ratio between the number of rotational speed values in the first preset interval and N among the N rotational speed values of each group, as the corresponding time interval corresponding to the rotational speed avoidance duration accounted for ratio, where M is an integer greater than 1, and N is an integer greater than 1.
- the preset standard ratio may be determined based on at least one of the following items: the time required for the wind turbine generator to pass through the avoidance speed interval from low speed to high speed, The down-jump duration required for the rotation speed interval, the preset number of times that the rotation speed avoidance interval can be normally crossed within the preset duration, and the length of the preset duration.
- the preset standard ratio may be: T max *I*J/L, where T max indicates the maximum value among the jump-up duration and the jump-down duration, I indicates the margin coefficient, J Indicates the preset number of times that the rotation speed avoidance interval can be normally traversed within the preset time period, and L indicates the length of the preset time period.
- the adjusted rotational speed avoidance control parameters may include at least one of the following items: a jump-up waiting time, a jump-down waiting time, a first electromagnetic torque, and a second electromagnetic torque, wherein the jump-up waiting time is: The time that the rotation speed needs to be at the lower boundary value of the avoidance speed range and the electromagnetic torque needs to stay at the first electromagnetic torque before crossing the avoidance speed interval from low speed to high speed, the jump waiting time is: The time that the rotational speed needs to be at the upper boundary value of the rotational speed avoidance interval and the electromagnetic torque needs to stay at the second electromagnetic torque before the rotational speed crosses the avoidance speed interval, wherein the avoidance speed interval is the open interval.
- the adjustment unit 20 may increase the up-jump waiting time and the down-jump waiting time, and/or increase the first electromagnetic torque and decrease the second electromagnetic torque, according to the statistical information that the rotation speed is in the rotation speed avoidance range.
- the adjustment unit 20 may adjust the rotational speed avoidance control parameter of the wind turbine according to the distribution of the rotational speed avoidance duration corresponding to the time interval in which the corresponding rotational speed avoidance duration ratio exceeds the preset standard ratio in the historical operation period. .
- the adjustment unit 20 may adjust the wind power generation when the proportion of the corresponding rotational speed avoidance durations in the historical operation period exceeds a preset standard proportion and the number of time intervals corresponding to the preset wind speed segment exceeds a second preset number
- the adjustment unit 20 may determine the avoidance speed according to the distribution of the ratio of the rotation speed avoidance duration corresponding to the time interval corresponding to the preset wind speed segment in the historical operation period that exceeds the preset standard ratio and the rotation speed avoidance duration ratio.
- the adjustment amount of the rotational speed control parameter, and the corresponding rotational speed avoidance control parameter is adjusted based on the determined adjustment amount, wherein the preset wind speed segment is a wind speed segment near the wind speed segment corresponding to the rotational speed avoidance interval.
- the proportion of the corresponding rotation speed avoidance duration in the historical operation period exceeds the preset standard ratio and the ratio of the rotation speed avoidance duration corresponding to the time interval corresponding to the preset wind speed segment, and the distance away from the preset standard ratio is greater.
- each unit in the rotational speed avoidance control device for a wind turbine may be implemented as hardware components and/or software components.
- Those skilled in the art can implement each device using, for example, a Field Programmable Gate Array (FPGA) or an Application Specific Integrated Circuit (ASIC) according to the processes performed by the respective devices as defined.
- FPGA Field Programmable Gate Array
- ASIC Application Specific Integrated Circuit
- an exemplary embodiment of the present disclosure also provides a wind power generator set, as shown in FIG. 2
- the wind power generator set includes a generator, a converter, a data acquisition module (not shown in the figure) and a controller
- the generator includes a stator and a rotor mechanically connected to the impeller; the converter is electrically coupled to the stator winding; the data acquisition module is configured to collect the rotational speed of the generator rotor; the controller is configured to set the converter The electromagnetic torque parameter to control the current in the stator windings, thereby controlling the rotational speed of the generator rotor.
- the controller is configured to execute the avoidance speed control method of the wind turbine as described in the above-mentioned exemplary embodiments.
- the data acquisition module may include a rotational speed sensor.
- the data collection module can also be configured to collect information such as electromagnetic torque, ambient wind speed, and the like of the wind turbine.
- an exemplary embodiment of the present disclosure also provides a wind power generator set, as shown in FIG. 2
- the wind power generator set includes a generator, a converter, a data acquisition module (not shown in the figure) and a controller
- the generator includes a stator and a rotor mechanically connected to the impeller; the converter is electrically coupled to the stator winding; the data acquisition module is configured to collect the rotational speed of the generator rotor; the controller is configured to set the converter The electromagnetic torque parameter to control the current in the stator windings, thereby controlling the rotational speed of the generator rotor.
- the controller includes the rotational speed avoidance control device of the wind turbine according to the above-mentioned exemplary embodiment.
- Exemplary embodiments of the present disclosure also provide a computer-readable storage medium storing a computer program, which, when the computer program is executed by a processor, implements the rotational speed avoidance control method for a wind turbine according to the above-mentioned exemplary embodiment .
- the computer-readable storage medium is any data storage device that can store data read by a computer system. Examples of computer-readable storage media include read-only memory, random-access memory, optical disks, magnetic tapes, floppy disks, optical data storage devices, and carrier waves (such as data transmission over the Internet via wired or wireless transmission paths).
Landscapes
- Engineering & Computer Science (AREA)
- Life Sciences & Earth Sciences (AREA)
- Sustainable Development (AREA)
- Sustainable Energy (AREA)
- Chemical & Material Sciences (AREA)
- Combustion & Propulsion (AREA)
- Mechanical Engineering (AREA)
- General Engineering & Computer Science (AREA)
- Wind Motors (AREA)
- Control Of Eletrric Generators (AREA)
Abstract
Description
Claims (16)
- 一种风力发电机组的避转速控制方法,其特征在于,所述方法包括:根据发电机的转速处于避转速区间的统计信息,识别风力发电机组是否反复通过避转速区间;当确定风力发电机组反复通过避转速区间时,根据转速处于避转速区间的统计信息,调整风力发电机组的避转速控制参数。
- 根据权利要求1所述的方法,其特征在于,发电机的转速处于避转速区间的统计信息包括:发电机的转速处于避转速区间的统计时长和/或进入避转速区间的统计次数。
- 根据权利要求2所述的方法,其特征在于,根据发电机的转速处于避转速区间的统计时长识别风力发电机组是否反复通过避转速区间的步骤包括:根据风力发电机组的历史运行时段的运行数据,确定所述历史运行时段中的每个时间间隔对应的避转速时长占比,其中,每个时间间隔对应的避转速时长占比为:该时间间隔内转速处于避转速区间之中的第一预设区间的总时长占预设时长的比例;当所述历史运行时段之中对应的避转速时长占比超过预设标准比例的时间间隔的总数量超过第一预设数量时,确定风力发电机组反复通过避转速区间,其中,每个时间间隔的长度为所述预设时长。
- 根据权利要求3所述的方法,其特征在于,所述预设标准比例基于以下项之中的至少一项而确定:风力发电机组从低转速向高转速穿越避转速区间所需的上跳时长、从高转速向低转速穿越避转速区间所需的下跳时长、预设的在所述预设时长内正常可穿越避转速区间的次数、以及所述预设时长的长度。
- 根据权利要求4所述的方法,其特征在于,所述预设标准比例为:T max*I*J/L,其中,T max指示所述上跳时长和所述下跳时长之中的最大值、I指示余量系数、J指示预设的在所述预设时长内正常可穿越避转速区间的次数、L指示所述预设时长的长度。
- 根据权利要求1所述的方法,其特征在于,调整的避转速控制参数包 括以下项之中的至少一项:上跳等待时间、下跳等待时间、第一电磁扭矩以及第二电磁扭矩,其中,所述上跳等待时间为:在从低转速向高转速穿越避转速区间之前转速需在避转速区间的下边界值且电磁扭矩需在第一电磁扭矩处停留的时间,所述下跳等待时间为:在从高转速向低转速穿越避转速区间之前转速需在避转速区间的上边界值且电磁扭矩需在第二电磁扭矩处停留的时间,其中,避转速区间为开区间。
- 根据权利要求6所述的方法,其特征在于,根据转速处于避转速区间的统计信息,调整风力发电机组的避转速控制参数的步骤包括:根据转速处于避转速区间的统计信息,增大上跳等待时间和下跳等待时间,和/或,增大第一电磁扭矩并减小第二电磁扭矩。
- 根据权利要求3所述的方法,其特征在于,根据转速处于避转速区间的统计信息,调整风力发电机组的避转速控制参数的步骤包括:根据所述历史运行时段之中对应的避转速时长占比超过预设标准比例的时间间隔所对应的避转速时长占比的分布,调整风力发电机组的避转速控制参数。
- 根据权利要求8所述的方法,其特征在于,根据所述历史运行时段之中对应的避转速时长占比超过预设标准比例的时间间隔所对应的避转速时长占比的分布,调整风力发电机组的避转速控制参数的步骤包括:当所述历史运行时段之中对应的避转速时长占比超过预设标准比例且对应于预设风速段的时间间隔的数量超过第二预设数量时,调整风力发电机组的避转速控制参数,其中,所述预设风速段为在避转速区间所对应的风速段附近的风速段。
- 根据权利要求8所述的方法,其特征在于,根据所述历史运行时段之中对应的避转速时长占比超过预设标准比例的时间间隔所对应的避转速时长占比的分布,调整风力发电机组的避转速控制参数的步骤包括:根据所述历史运行时段之中对应的避转速时长占比超过预设标准比例且对应于预设风速段的时间间隔所对应的避转速时长占比的分布,确定避转速控制参数的调整量,并基于确定的调整量调整对应的避转速控制参数,其中,所述预设风速段为在避转速区间所对应的风速段附近的风速段。
- 根据权利要求10所述的方法,其特征在于,所述历史运行时段之中对应的避转速时长占比超过预设标准比例且对应于预设风速段的时间间隔所对应的避转速时长占比,远离预设标准比例的远离程度越大和/或远离预设标准比例的数量越多,避转速控制参数的调整量越大。
- 一种风力发电机组的避转速控制装置,其特征在于,所述装置包括:异常识别单元,根据发电机的转速处于避转速区间的统计信息,识别风力发电机组是否反复通过避转速区间;调整单元,当确定风力发电机组反复通过避转速区间时,根据转速处于避转速区间的统计信息,调整风力发电机组的避转速控制参数。
- 一种风力发电机组,其特征在于,包括:发电机,其包括定子和与叶轮机械连接的转子;变流器,其与定子绕组电性耦合连接;数据采集模块,被配置为采集发电机转子的转速;控制器,被配置为设置变流器的电磁扭矩参数以控制发电机的转速,所述控制器执行如权利要求1至11中的任意一项所述的避转速控制方法。
- 根据权利要求13所述的风力发电机组,其特征在于,所述发电机为永磁发电机,所述风力发电机组为直驱型。
- 一种风力发电机组,其特征在于,包括:发电机,其包括定子和与叶轮机械连接的转子;变流器,其与定子绕组电性耦合连接;数据采集模块,被配置为采集发电机转子的转速;控制器,被配置为设置变流器的电磁扭矩参数以控制发电机的转速,所述控制器包括如权利要求12所述的避转速控制装置。
- 一种存储有计算机程序的计算机可读存储介质,其特征在于,当所述计算机程序被处理器执行时实现如权利要求1至11中的任意一项所述的风力发电机组的避转速控制方法。
Priority Applications (7)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| EP21833226.0A EP4130460B1 (en) | 2020-06-28 | 2021-03-30 | Wind turbine generator system, and rotation speed avoidance control method and apparatus therefor |
| CA3181328A CA3181328A1 (en) | 2020-06-28 | 2021-03-30 | Wind turbine generator system, and rotation speed avoidance control method and apparatus therefor |
| BR112022024885-7A BR112022024885B1 (pt) | 2020-06-28 | 2021-03-30 | Sistema de gerador de turbina eólica, e método de controle de evasão de velocidade de rotação e aparelho para o mesmo |
| AU2021303190A AU2021303190B2 (en) | 2020-06-28 | 2021-03-30 | Wind turbine generator system, and rotation speed avoidance control method and apparatus therefor |
| ES21833226T ES3004132T3 (en) | 2020-06-28 | 2021-03-30 | Wind turbine generator system, and rotation speed avoidance control method and apparatus therefor |
| US17/997,379 US12092080B2 (en) | 2020-06-28 | 2021-03-30 | Wind turbine generator system, and rotation speed avoidance control method and apparatus therefor |
| ZA2022/12231A ZA202212231B (en) | 2020-06-28 | 2022-11-09 | Wind turbine generator system, and rotation speed avoidance control method and apparatus therefor |
Applications Claiming Priority (2)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| CN202010597154.9 | 2020-06-28 | ||
| CN202010597154.9A CN113847196B (zh) | 2020-06-28 | 2020-06-28 | 风力发电机组及其避转速控制方法、装置 |
Publications (1)
| Publication Number | Publication Date |
|---|---|
| WO2022001248A1 true WO2022001248A1 (zh) | 2022-01-06 |
Family
ID=78972580
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| PCT/CN2021/083977 Ceased WO2022001248A1 (zh) | 2020-06-28 | 2021-03-30 | 风力发电机组及其避转速控制方法、装置 |
Country Status (9)
| Country | Link |
|---|---|
| US (1) | US12092080B2 (zh) |
| EP (1) | EP4130460B1 (zh) |
| CN (1) | CN113847196B (zh) |
| AU (1) | AU2021303190B2 (zh) |
| CA (1) | CA3181328A1 (zh) |
| CL (1) | CL2022003461A1 (zh) |
| ES (1) | ES3004132T3 (zh) |
| WO (1) | WO2022001248A1 (zh) |
| ZA (1) | ZA202212231B (zh) |
Cited By (1)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN116090309A (zh) * | 2023-02-20 | 2023-05-09 | 华北电力大学 | 风力发电机组仿真模型的生成方法、装置、设备及介质 |
Families Citing this family (4)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN113847195B (zh) | 2020-06-28 | 2023-06-02 | 北京金风科创风电设备有限公司 | 风力发电机组及其避转速控制方法、装置 |
| CN114645820A (zh) * | 2022-03-29 | 2022-06-21 | 上海电气风电集团股份有限公司 | 风力发电机控制方法及其系统及计算机可读存储介质 |
| CN116842319B (zh) * | 2023-06-30 | 2026-02-27 | 华能湖南苏宝顶风电有限责任公司 | 一种风力发电机组转速执行偏差辨识方法及系统 |
| CN122236597B (zh) * | 2026-05-21 | 2026-07-24 | 内蒙古工业大学 | 一种基于湍流环境的风电机组智能控制方法及系统 |
Citations (5)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| WO2012139584A1 (en) * | 2011-04-15 | 2012-10-18 | Vestas Wind Systems A/S | A method for adapting wind turbine power production to a power demand |
| CN103147916A (zh) * | 2013-02-19 | 2013-06-12 | 广东明阳风电产业集团有限公司 | 一种避开风电塔架固有频率点的控制方法 |
| CN103758698A (zh) * | 2014-01-22 | 2014-04-30 | 北京金风科创风电设备有限公司 | 用于风电机组的转速控制方法和系统 |
| CN104405581A (zh) * | 2014-10-24 | 2015-03-11 | 北京金风科创风电设备有限公司 | 风力发电机组转速控制方法及控制系统 |
| CN107514337A (zh) * | 2016-06-17 | 2017-12-26 | 北京天诚同创电气有限公司 | 风力发电机组的控制方法、装置及风电场群控系统 |
Family Cites Families (11)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN103762919B (zh) * | 2014-01-09 | 2017-01-04 | 华北电力大学 | 用于直驱式风力发电机低电压穿越的功率控制装置及方法 |
| CN104298266B (zh) * | 2014-10-08 | 2017-02-15 | 北京金风科创风电设备有限公司 | 用于风力发电机组的共振控制方法及控制系统 |
| WO2017211367A1 (en) * | 2016-06-07 | 2017-12-14 | Vestas Wind Systems A/S | Adaptive control of a wind turbine by detecting a change in performance |
| EP3707375B1 (en) | 2017-11-06 | 2022-07-06 | Vestas Wind Systems A/S | Method and system for controlling a wind turbine to manage edgewise blade vibrations |
| CN108425796A (zh) * | 2018-01-30 | 2018-08-21 | 南京风电科技有限公司 | 一种避免风电机组同时穿越塔筒共振区的控制方法 |
| DE102018102863A1 (de) | 2018-02-08 | 2019-08-08 | Wobben Properties Gmbh | Verfahren zum Steuern einer Windenergieanlage und entsprechende Windenergieanlage |
| CN108590956A (zh) * | 2018-04-27 | 2018-09-28 | 国电联合动力技术有限公司 | 一种风电机组塔筒共振避让穿越控制方法及风电机组 |
| CN108923473B (zh) * | 2018-09-14 | 2020-09-08 | 国电联合动力技术有限公司 | 一种基于智能穿越技术的柔塔风电场能量调度方法及系统 |
| CN110344959B (zh) * | 2019-06-26 | 2022-03-11 | 中国第一汽车股份有限公司 | 一种共振抑制方法、装置及车辆 |
| CN110671265B (zh) * | 2019-10-24 | 2020-11-06 | 合肥鼎优电气有限公司 | 一种风力发电机防共振控制方法及装置 |
| CN113847197B (zh) * | 2020-06-28 | 2023-02-28 | 北京金风科创风电设备有限公司 | 风力发电机组及其避转速控制方法、装置 |
-
2020
- 2020-06-28 CN CN202010597154.9A patent/CN113847196B/zh active Active
-
2021
- 2021-03-30 US US17/997,379 patent/US12092080B2/en active Active
- 2021-03-30 EP EP21833226.0A patent/EP4130460B1/en active Active
- 2021-03-30 CA CA3181328A patent/CA3181328A1/en active Pending
- 2021-03-30 ES ES21833226T patent/ES3004132T3/es active Active
- 2021-03-30 WO PCT/CN2021/083977 patent/WO2022001248A1/zh not_active Ceased
- 2021-03-30 AU AU2021303190A patent/AU2021303190B2/en active Active
-
2022
- 2022-11-09 ZA ZA2022/12231A patent/ZA202212231B/en unknown
- 2022-12-06 CL CL2022003461A patent/CL2022003461A1/es unknown
Patent Citations (5)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| WO2012139584A1 (en) * | 2011-04-15 | 2012-10-18 | Vestas Wind Systems A/S | A method for adapting wind turbine power production to a power demand |
| CN103147916A (zh) * | 2013-02-19 | 2013-06-12 | 广东明阳风电产业集团有限公司 | 一种避开风电塔架固有频率点的控制方法 |
| CN103758698A (zh) * | 2014-01-22 | 2014-04-30 | 北京金风科创风电设备有限公司 | 用于风电机组的转速控制方法和系统 |
| CN104405581A (zh) * | 2014-10-24 | 2015-03-11 | 北京金风科创风电设备有限公司 | 风力发电机组转速控制方法及控制系统 |
| CN107514337A (zh) * | 2016-06-17 | 2017-12-26 | 北京天诚同创电气有限公司 | 风力发电机组的控制方法、装置及风电场群控系统 |
Non-Patent Citations (1)
| Title |
|---|
| See also references of EP4130460A4 * |
Cited By (3)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN116090309A (zh) * | 2023-02-20 | 2023-05-09 | 华北电力大学 | 风力发电机组仿真模型的生成方法、装置、设备及介质 |
| CN116090309B (zh) * | 2023-02-20 | 2023-08-01 | 华北电力大学 | 风力发电机组仿真模型的生成方法、装置、设备及介质 |
| US12197828B2 (en) | 2023-02-20 | 2025-01-14 | North China Electric Power University | Method and device for generating wind turbine generator set simulation model, equipment, and medium |
Also Published As
| Publication number | Publication date |
|---|---|
| US12092080B2 (en) | 2024-09-17 |
| EP4130460C0 (en) | 2024-10-30 |
| CN113847196A (zh) | 2021-12-28 |
| CA3181328A1 (en) | 2022-01-06 |
| EP4130460A4 (en) | 2023-09-20 |
| ZA202212231B (en) | 2024-04-24 |
| ES3004132T3 (en) | 2025-03-11 |
| AU2021303190A1 (en) | 2022-12-01 |
| US20230213018A1 (en) | 2023-07-06 |
| BR112022024885A2 (pt) | 2023-01-24 |
| EP4130460B1 (en) | 2024-10-30 |
| AU2021303190B2 (en) | 2024-02-15 |
| CL2022003461A1 (es) | 2023-06-02 |
| CN113847196B (zh) | 2023-06-06 |
| EP4130460A1 (en) | 2023-02-08 |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| CN113847196B (zh) | 风力发电机组及其避转速控制方法、装置 | |
| WO2022001250A1 (zh) | 风力发电机组及其避转速控制方法、装置 | |
| US7573149B2 (en) | System and method for controlling a wind power plant | |
| US10100812B2 (en) | Methods and systems to operate a wind turbine system | |
| CN107514337B (zh) | 风力发电机组的控制方法、装置及风电场群控系统 | |
| US20170335827A1 (en) | System and Method for Determining Wind Farm Wake Loss | |
| CN113847197B (zh) | 风力发电机组及其避转速控制方法、装置 | |
| EP3737857B1 (en) | A method for controlling a wind energy farm taking wake effects into account | |
| US11965483B2 (en) | Method for operating a wind farm, wind power installation and wind farm | |
| EP3406897A1 (en) | System and method for determining wind farm wake loss | |
| CN117028129A (zh) | 基于物联网的同轴水轮机智能控制系统 | |
| US12021477B2 (en) | Method for controlling a wind turbine | |
| US20230003191A1 (en) | Wind turbine control | |
| BR112022024885B1 (pt) | Sistema de gerador de turbina eólica, e método de controle de evasão de velocidade de rotação e aparelho para o mesmo | |
| BR112022024994B1 (pt) | Gerador de turbina eólica, e método de controle de velocidade giratória mínima e dispositivo para o mesmo | |
| BR112022024196B1 (pt) | Sistema de gerador de turbina eólica e método de controle de evasão de velocidade de rotação e aparelho para o mesmo | |
| CN121461268A (zh) | 一种风电场等值建模方法、系统、设备、介质及程序产品 |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| 121 | Ep: the epo has been informed by wipo that ep was designated in this application |
Ref document number: 21833226 Country of ref document: EP Kind code of ref document: A1 |
|
| ENP | Entry into the national phase |
Ref document number: 3181328 Country of ref document: CA |
|
| ENP | Entry into the national phase |
Ref document number: 2021833226 Country of ref document: EP Effective date: 20221026 |
|
| WWE | Wipo information: entry into national phase |
Ref document number: 202217066843 Country of ref document: IN |
|
| ENP | Entry into the national phase |
Ref document number: 2021303190 Country of ref document: AU Date of ref document: 20210330 Kind code of ref document: A |
|
| REG | Reference to national code |
Ref country code: BR Ref legal event code: B01A Ref document number: 112022024885 Country of ref document: BR |
|
| ENP | Entry into the national phase |
Ref document number: 112022024885 Country of ref document: BR Kind code of ref document: A2 Effective date: 20221206 |
|
| NENP | Non-entry into the national phase |
Ref country code: DE |