WO2023048078A1 - 工作機械、制御方法、および制御プログラム - Google Patents
工作機械、制御方法、および制御プログラム Download PDFInfo
- Publication number
- WO2023048078A1 WO2023048078A1 PCT/JP2022/034708 JP2022034708W WO2023048078A1 WO 2023048078 A1 WO2023048078 A1 WO 2023048078A1 JP 2022034708 W JP2022034708 W JP 2022034708W WO 2023048078 A1 WO2023048078 A1 WO 2023048078A1
- Authority
- WO
- WIPO (PCT)
- Prior art keywords
- tooling
- machine tool
- hsk
- unit
- holding portion
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Ceased
Links
Images





Classifications
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B23—MACHINE TOOLS; METAL-WORKING NOT OTHERWISE PROVIDED FOR
- B23Q—DETAILS, COMPONENTS, OR ACCESSORIES FOR MACHINE TOOLS, e.g. ARRANGEMENTS FOR COPYING OR CONTROLLING; MACHINE TOOLS IN GENERAL CHARACTERISED BY THE CONSTRUCTION OF PARTICULAR DETAILS OR COMPONENTS; COMBINATIONS OR ASSOCIATIONS OF METAL-WORKING MACHINES, NOT DIRECTED TO A PARTICULAR RESULT
- B23Q17/00—Arrangements for observing, indicating or measuring on machine tools
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B23—MACHINE TOOLS; METAL-WORKING NOT OTHERWISE PROVIDED FOR
- B23Q—DETAILS, COMPONENTS, OR ACCESSORIES FOR MACHINE TOOLS, e.g. ARRANGEMENTS FOR COPYING OR CONTROLLING; MACHINE TOOLS IN GENERAL CHARACTERISED BY THE CONSTRUCTION OF PARTICULAR DETAILS OR COMPONENTS; COMBINATIONS OR ASSOCIATIONS OF METAL-WORKING MACHINES, NOT DIRECTED TO A PARTICULAR RESULT
- B23Q15/00—Automatic control or regulation of feed movement, cutting velocity or position of tool or work
- B23Q15/007—Automatic control or regulation of feed movement, cutting velocity or position of tool or work while the tool acts upon the workpiece
- B23Q15/12—Adaptive control, i.e. adjusting itself to have a performance which is optimum according to a preassigned criterion
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B23—MACHINE TOOLS; METAL-WORKING NOT OTHERWISE PROVIDED FOR
- B23Q—DETAILS, COMPONENTS, OR ACCESSORIES FOR MACHINE TOOLS, e.g. ARRANGEMENTS FOR COPYING OR CONTROLLING; MACHINE TOOLS IN GENERAL CHARACTERISED BY THE CONSTRUCTION OF PARTICULAR DETAILS OR COMPONENTS; COMBINATIONS OR ASSOCIATIONS OF METAL-WORKING MACHINES, NOT DIRECTED TO A PARTICULAR RESULT
- B23Q17/00—Arrangements for observing, indicating or measuring on machine tools
- B23Q17/002—Arrangements for observing, indicating or measuring on machine tools for indicating or measuring the holding action of work or tool holders
- B23Q17/003—Arrangements for observing, indicating or measuring on machine tools for indicating or measuring the holding action of work or tool holders by measuring a position
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B23—MACHINE TOOLS; METAL-WORKING NOT OTHERWISE PROVIDED FOR
- B23Q—DETAILS, COMPONENTS, OR ACCESSORIES FOR MACHINE TOOLS, e.g. ARRANGEMENTS FOR COPYING OR CONTROLLING; MACHINE TOOLS IN GENERAL CHARACTERISED BY THE CONSTRUCTION OF PARTICULAR DETAILS OR COMPONENTS; COMBINATIONS OR ASSOCIATIONS OF METAL-WORKING MACHINES, NOT DIRECTED TO A PARTICULAR RESULT
- B23Q17/00—Arrangements for observing, indicating or measuring on machine tools
- B23Q17/24—Arrangements for observing, indicating or measuring on machine tools using optics or electromagnetic waves
- B23Q17/2452—Arrangements for observing, indicating or measuring on machine tools using optics or electromagnetic waves for measuring features or for detecting a condition of machine parts, tools or workpieces
- B23Q17/2476—Arrangements for observing, indicating or measuring on machine tools using optics or electromagnetic waves for measuring features or for detecting a condition of machine parts, tools or workpieces of clamping devices, e.g. work or tool holders
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B23—MACHINE TOOLS; METAL-WORKING NOT OTHERWISE PROVIDED FOR
- B23Q—DETAILS, COMPONENTS, OR ACCESSORIES FOR MACHINE TOOLS, e.g. ARRANGEMENTS FOR COPYING OR CONTROLLING; MACHINE TOOLS IN GENERAL CHARACTERISED BY THE CONSTRUCTION OF PARTICULAR DETAILS OR COMPONENTS; COMBINATIONS OR ASSOCIATIONS OF METAL-WORKING MACHINES, NOT DIRECTED TO A PARTICULAR RESULT
- B23Q3/00—Devices holding, supporting, or positioning work or tools, of a kind normally removable from the machine
- B23Q3/155—Arrangements for automatic insertion or removal of tools, e.g. combined with manual handling
Definitions
- the present disclosure relates to machine tools, control methods, and control programs.
- Patent Literature 1 discloses a machine tool whose purpose is to detect abnormal attachment of a tool holder.
- the machine tool "determines whether or not the tool holder is attached to the spindle based on the change over time in the amount of displacement of the outer peripheral surface of the flange of the tool holder.”
- the tool is attached to the machine tool via the tooling. That is, the tooling functions as a connecting interface between the tool and the machine tool.
- a tooling consists of a tool holder that holds the tool and a shank that connects to the machine tool.
- Shank standards include, for example, BT shanks, BBT shanks, and HSK shanks.
- the machine tool disclosed in Patent Literature 1 detects a mounting abnormality with respect to a BT shank or BBT shank tool holder.
- the HSK shank has two grooves with different depths.
- a tooling holder such as a spindle or a magazine
- the two grooves of the HSK shank are engaged with one or two engaging sections provided on the tooling holder. This secures the tooling to the tooling holder.
- the two grooves provided on the HSK shank are provided facing each other. Since the depth difference between the grooves is very small, the HSK shank may be installed in the tooling retainer 180 degrees from what it should be. If machining is performed while the HSK shank is abnormally attached to the tooling holding portion, the machining accuracy of the workpiece may deteriorate. There is also the possibility that the HSK shank will drop during machining of the workpiece. A dropped HSK shank can damage the workpiece, tool, or machine tool body. Accordingly, there is a need for techniques for detecting misalignment of HSK shanks to machine tools.
- a machine tool in one example of the present disclosure, includes a tooling holder having a tooling insertion opening.
- the tooling includes a tool holder for holding a tool and an HSK shank inserted into the insertion opening.
- the machine tool further includes a detection section for detecting physical information indicating the state of the gap between the tooling and the tooling holding section, and a control section for controlling the machine tool.
- the control unit includes an acquisition unit for acquiring the physical information from the detection unit while the tooling is attached to the tooling holding unit; a determination unit for determining whether or not the tooling is normally attached to the tooling holding portion; and a predetermined process is executed when it is determined that the tooling is not normally attached to the tooling holding portion. and an execution part for
- the detection unit includes a camera.
- the camera acquires an image representing the gap as the physical information.
- the tooling holding portion includes an interlocking member that interlocks with the HSK shank when the HSK shank is inserted into the insertion opening.
- the detection unit includes a position sensor for detecting the position of the interlocking member as the physical information.
- the HSK shank has a cylindrical portion.
- the cylindrical portion includes a first groove having a first depth in the direction of the central axis of the cylindrical portion and a second groove having a second depth in the direction. The second depth is different than the first depth.
- the tooling holding portion includes a first engaging portion that engages with the first groove portion when the HSK shank is inserted into the insertion opening, and a second engaging portion that engages with the first groove portion when the HSK shank is inserted into the insertion opening. and a second engaging portion that engages the groove.
- the determination unit determines that the tooling is not normally attached to the tooling holding unit when the physical information indicates that the width of the gap is equal to or greater than a predetermined value.
- the tooling holding section includes at least one of a magazine, a spindle, and a tool post.
- the machine tool includes a tooling holder having a tooling insertion opening.
- the tooling includes a tool holder for holding a tool and an HSK shank inserted into the insertion opening.
- the machine tool further includes a detection section for detecting physical information indicating the state of the gap between the tooling and the tooling holding section.
- the control method includes the step of acquiring the physical information from the detection unit while the tooling is attached to the tooling holding unit; and a step of performing predetermined processing when it is determined that the tooling is not normally attached to the tooling holding part.
- the machine tool includes a tooling holder having a tooling insertion opening.
- the tooling includes a tool holder for holding a tool and an HSK shank inserted into the insertion opening.
- the machine tool further includes a detection section for detecting physical information indicating the state of the gap between the tooling and the tooling holding section.
- the control program comprises a step of acquiring the physical information from the detection unit while the tooling is attached to the tooling holding unit of the machine tool; is normally attached to the tooling holding portion; and executing a predetermined process when it is determined that the tooling is not normally attached to the tooling holding portion.
- FIG. 1 is a perspective view of an HSK tooling
- FIG. FIG. 4 is a side view of the HSK tooling viewed from the X-axis direction shown in FIG. 3
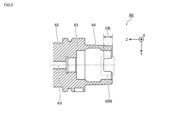
- FIG. 4 is a view showing a cross section of the HSK tooling from the X-axis direction shown in FIG. 3
- FIG. 4 is a diagram schematically showing how the HSK tooling is attached to the tooling holding portion
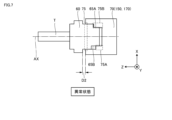
- FIG. 4 is a diagram schematically showing how the HSK tooling is attached to the tooling holding portion
- FIG. 4 is a conceptual diagram schematically showing a process of detecting mounting abnormality of HSK tooling
- FIG. 2 is a diagram showing an example of the hardware configuration of a CPU (Central Processing Unit) unit
- CPU Central Processing Unit
- CNC Computer Numerical Control
- FIG. 4 is a flow chart showing part of the processing executed by the control unit of the machine tool
- FIG. 4 is a diagram schematically showing how the HSK tooling is attached to the tooling holding portion
- FIG. 4 is a diagram schematically showing how the HSK tooling is attached to the tooling holding portion
- FIG. 5 is a diagram showing an example of a functional configuration of a machine tool according to a modified example
- FIG. 5 is a diagram showing an example of a functional configuration of a machine tool according to a modified example
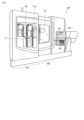
- FIG. 1 is a diagram showing the appearance of a machine tool 100. As shown in FIG.
- Machine tool as used in this specification is a concept that includes various devices equipped with the function of machining a workpiece.
- the machine tool 100 may be a horizontal machining center or a vertical machining center.
- machine tool 100 may be a lathe, an additional processing machine, or other cutting or grinding machine.
- the machine tool 100 has a tool storage section 40A and a processing machine main body 40B. Each of the tool storage section 40A and the processing machine body 40B is compartmentalized by a cover.
- a magazine 150 and an ATC (Automatic Tool Changer) 160 are provided in the tool storage section 40A.
- a main shaft 170 is provided in the processing machine main body 40B.
- a worker can attach a tool to the magazine 150 through the door D1.
- the processing machine main body 40B uses at least one of the plurality of tools held in the magazine 150 to process the workpiece.
- the machine tool 100 drives the magazine 150 to move one tool corresponding to the machining process (hereinafter also referred to as the "next tool to be used”) to the first tool change position.
- the machine tool 100 also drives the spindle 170 to move the tool attached to the spindle 170 (hereinafter also referred to as "used tool”) to the second tool change position.
- the ATC 160 replaces the next used tool waiting at the first tool changing position with the used tool waiting at the second tool changing position.
- Tools are exchanged through a door D2 provided in a partition between the processing machine main body 40B and the tool storage section 40A.
- the door D2 is, for example, a sliding door, and is opened and closed by a drive source such as a motor.
- the spindle 170 processes the workpiece using the mounted next-use tool.
- the machine tool 100 is provided with an operation panel 500 .
- the operation panel 500 includes a display 505 for displaying various information regarding machining, and operation keys 506 for accepting various operations for the machine tool 100 .
- FIG. 2 is a diagram showing an example of a drive mechanism of the machine tool 100. As shown in FIG.
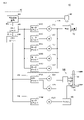
- the machine tool 100 includes a control section 50, drive sections 110, 120, 130, a magazine 150, an ATC 160, and a spindle 170.
- the direction of gravity is hereinafter also referred to as the "X-axis direction”.
- One direction on the horizontal plane perpendicular to the X-axis is also referred to as "Y-axis direction”.
- a direction perpendicular to both the X-axis direction and the Y-axis direction is referred to as a "Z-axis direction.”
- control unit 50 means a device that controls the machine tool 100.
- the device configuration of the control unit 50 is arbitrary.
- the control section 50 may be composed of a single control unit, or may be composed of a plurality of control units.
- the control section 50 is composed of a CPU unit 200 , a CNC unit 300 and an information processing device 400 .
- the control unit 50 may include the operation panel 500 (see FIG. 1) described above.
- the CPU unit 200 and CNC unit 300 communicate with each other via bus B, for example.
- CNC unit 300 and information processing device 400 communicate with each other, for example, via network NW.
- the CPU unit 200 is, for example, a PLC (Programmable Logic Controller).
- the CPU unit 200 controls the driving section 110 according to a predesigned PLC program.
- the PLC program is written in, for example, a ladder program.
- the drive unit 110 is a drive mechanism for rotating the magazine 150 .
- the device configuration of the drive unit 110 is arbitrary.
- the driving section 110 may be composed of a single driving unit, or may be composed of a plurality of driving units. In the example of FIG. 2, the driving section 110 is composed of a motor driver 111M and a motor 112M.
- the motor driver 111M drives the magazine 150 according to control instructions from the CPU unit 200.
- the magazine 150 is provided with a motor 112M.
- the motor 112M may be a servo motor, a stepping motor, or any other type of motor.
- the motor driver 111M receives input of the target rotation speed from the CPU unit 200 and controls the motor 112M.
- the motor 112M rotationally drives the magazine 150 according to the output current from the motor driver 111M, and drives the specified next use tool T1 in the magazine 150 to the specified position.
- Drive unit 120 is a drive mechanism for driving ATC 160 .
- the device configuration of the drive unit 120 is arbitrary.
- the driving section 120 may be composed of a single driving unit, or may be composed of a plurality of driving units. In the example of FIG. 2, the driving section 120 is composed of an ATC driver 121A and motors 122A and 122B.
- the ATC driver 121A is, for example, a two-axis integrated driver, and controls driving of motors 122A and 122B connected to the ATC 160.
- ATC 160 includes a central shaft 165 and arms 166 .
- Arm 166 is, for example, a double arm capable of holding two tools at the same time. That is, the arm 166 includes a tool gripping portion 166A extending from the central axis 165 in one direction (for example, the X-axis direction) orthogonal to the axial direction of the central axis 165, and a tool gripping portion 166A extending from the central axis 165 in the direction opposite to the one direction. and an extending tool gripper 166B.
- Each of the motors 122A and 122B may be a servo motor, a stepping motor, or other types of motors.
- ATC driver 121A receives, for example, a target rotation speed input for motor 122A and a target rotation speed input for motor 122B from CPU unit 200, and controls motors 122A and 122B.
- the motor 122A feeds and drives the arm 166 of the ATC 160 according to the output current from the ATC driver 121A, and drives the arm 166 to an arbitrary position in the axial direction of the center shaft 165.
- the motor 122B rotates the arm 166 of the ATC 160 in accordance with the output current from the ATC driver 121A, and drives the arm 166 to an arbitrary rotation angle with the central axis 165 as the center of rotation.
- the ATC 160 acquires the tool to be used next T1 from the magazine 150 based on receiving the tool replacement command. After that, the ATC 160 removes the used tool T2 from the spindle 170 and attaches the next tool T1 to the spindle 170 . After that, the ATC 160 stores the used tool T2 pulled out from the spindle 170 in the magazine 150 .
- the CNC unit 300 Upon receiving a machining start command from the CPU unit 200, the CNC unit 300 starts executing a pre-designed machining program.
- the machining program is written in, for example, an NC (Numerical Control) program.
- the CNC unit 300 drives the driving section 130 according to the machining program.
- the drive unit 130 is a drive mechanism for moving the main shaft 170 .
- the device configuration of the drive unit 130 is arbitrary.
- the driving section 130 may be composed of a single driving unit, or may be composed of a plurality of driving units.
- the driving section 130 is composed of motor drivers 131B, 131C, 131X, 131Y and 131Z and motors 132B, 132C, 132X, 132Y and 132Z.
- the motor driver 131B sequentially receives input of the target rotational speed from the CNC unit 300 and controls the motor 132B.
- the motor 132B rotationally drives the main shaft 170 about the Y-axis direction.
- the motor 132B may be an AC motor, a stepping motor, a servo motor, or any other type of motor.
- the motor driver 131B calculates the actual rotational speed of the motor 132B from a feedback signal from an encoder (not shown) for detecting the rotational angle of the motor 132B. Then, the motor driver 131B increases the rotation speed of the motor 132B when the calculated actual rotation speed is lower than the target rotation speed, and increases the rotation speed of the motor 132B when the calculated actual rotation speed is higher than the target rotation speed. lower the Thus, the motor driver 131B brings the rotational speed of the motor 132B closer to the target rotational speed while sequentially receiving the feedback of the rotational speed of the motor 132B.
- the motor driver 131C sequentially receives input of target positions from the CNC unit 300 and controls the motor 132C.
- the motor 132C rotationally drives the main shaft 170 with the axial direction of the main shaft 170 as the center of rotation.
- the motor 132C may be an AC motor, a stepping motor, a servo motor, or any other type of motor. Since the method of controlling motor 132C by motor driver 131C is the same as that of motor driver 131B, description thereof will not be repeated.
- the motor driver 131X sequentially receives input of target positions from the CNC unit 300 and controls the motor 132X.
- the motor 132X feeds and drives the main shaft 170 to move the main shaft 170 to an arbitrary position in the X-axis direction.
- the motor 132X may be an AC motor, a stepping motor, a servo motor, or any other type of motor. Since the method of controlling motor 132X by motor driver 131X is the same as that of motor driver 131B, description thereof will not be repeated.
- the motor driver 131Y sequentially receives input of target positions from the CNC unit 300 and controls the motor 132Y.
- the motor 132Y feeds and drives the main shaft 170 to move the main shaft 170 to an arbitrary position in the Y-axis direction.
- the motor 132Y may be an AC motor, a stepping motor, a servo motor, or any other type of motor. Since the method of controlling motor 132Y by motor driver 131Y is the same as that of motor driver 131B, description thereof will not be repeated.
- the motor driver 131Z sequentially receives input of target positions from the CNC unit 300 and controls the motor 132Z.
- the motor 132Z feeds and drives the main shaft 170 to move the main shaft 170 to an arbitrary position in the Z-axis direction.
- the motor 132Z may be an AC motor, a stepping motor, a servo motor, or any other type of motor. Since the method of controlling motor 132Z by motor driver 131Z is the same as that of motor driver 131B, description thereof will not be repeated.
- the information processing device 400 is a computer.
- the information processing apparatus 400 may be a desktop computer, a notebook computer, or a tablet terminal.
- a camera 180 is connected to the information processing device 400 .
- a predetermined image processing program is installed in the information processing device 400 , and the information processing device 400 detects abnormal mounting of the tool based on the input image from the camera 180 . Details of the detection process will be described later.
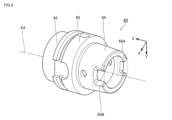
- FIG. 3 is a perspective view showing the HSK tooling 60.
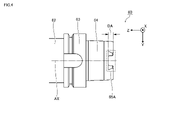
- FIG. 4 is a side view of the HSK tooling 60 viewed from the X-axis direction shown in FIG.
- FIG. 5 is a view showing a cross section of the HSK tooling 60 from the X-axis direction shown in FIG.
- HSK Tooling 60 is a type of tooling standard stipulated by ISO (International Organization for Standardization). HSK tooling 60 functions as a connection interface between tools and machine tool 100 .
- the HSK tooling 60 is composed of a tool holder 62 (tool holding portion), a flange 63 and an HSK shank 64.
- the tool holder 62 is configured to be able to hold a tool.
- the tool holder 62 is connected to one end of the flange 63 .
- the HSK shank 64 is connected to the other end of the flange 63.
- HSK shank 64 has a hollow cylindrical portion. The inner and outer surfaces of the cylindrical portion extend in the axial direction of the central axis AX.
- the axial direction of the central axis AX corresponds to the attachment/detachment direction of the tool with respect to the tool holder 62 .
- the HSK shank 64 also includes a groove portion 65A (first groove portion) having a depth "DA" in the axial direction of the central axis AX and a groove portion 65B (second groove portion) having a depth "DB" in the axial direction of the central axis AX. ) and
- the direction parallel to the central axis AX and the direction in which the tool is attached to and detached from the HSK tooling 60 is also referred to as the "Z-axis direction”.
- the direction perpendicular to the Z-axis direction which is the direction from the groove portion 65A to the groove portion 65B, is also referred to as the "X-axis direction.”
- a direction orthogonal to both the Z-axis direction and the X-axis direction is also referred to as a "Y-axis direction.”
- the groove portion 65A has a concave shape that is depressed in the Z-axis direction.
- the groove portion 65B has a concave shape that is depressed in the Z-axis direction.
- the groove portion 65A and the groove portion 65B are provided at positions opposed to each other about the central axis AX.
- the depth "DA" of the groove 65A in the Z-axis direction is different from the depth "DB" of the groove 65B in the Z-axis direction.
- the depth "DA" of groove 65A is shallower than the depth "DB" of groove 65B.
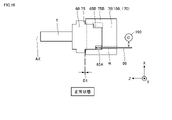
- FIGS. 6 and 7 schematically show how the HSK tooling 60 is attached to the tooling holder 70.
- FIG. 6 and 7 schematically show how the HSK tooling 60 is attached to the tooling holder 70.
- the HSK tooling 60 functions as a connection interface between the tool T and the tooling holder 70.
- tooling holder 70 means any unit capable of holding HSK tooling 60 .
- the tooling holding portion 70 include the above-described magazine 150 (see FIG. 1), the above-described ATC 160 (see FIG. 1), the above-described spindle 170 (see FIG. 1), or a tool rest (not shown).
- the tooling holding portion 70 has an insertion opening 75 for the HSK tooling 60 .
- the insertion opening 75 is formed in accordance with the shape of the HSK shank 64 described above.
- the HSK tooling 60 has grooves 65A recessed in the Z-axis direction.
- the tooling holding portion 70 has an engaging portion 75A (first engaging portion) that engages the groove portion 65A when the HSK shank 64 of the HSK tooling 60 is inserted into the insertion port 75 .
- the HSK tooling 60 also has a groove 65B recessed in the Z-axis direction.
- the tooling holding portion 70 has an engaging portion 75B (second engaging portion) that engages with the groove portion 65B when the HSK shank 64 of the HSK tooling 60 is inserted into the insertion port 75 .
- the width of the engaging portion 75A in the central axis AX direction is equal to the depth "DA" (see FIG. 4) of the groove portion 65A in the central axis AX direction.
- the width of the engaging portion 75B in the axial direction of the central axis AX is equal to the depth "DB" (see FIG. 5) of the groove portion 65B in the axial direction of the central axis AX.
- the width of the engaging portion 75B in the central axis AX direction is longer than the width of the engaging portion 75A in the central axis AX direction.
- the two grooves 65A and 65B provided in the HSK tooling 60 are provided facing each other around the central axis AX. Also, the depth of the groove portion 65A "DA ” and the depth “DB” of the groove portion 65B is very small, the HSK tooling 60 may be attached to the tooling holding portion 70 180 degrees reversed.
- FIG. 6 shows how the HSK tooling 60 is normally attached to the tooling holding portion 70 .
- the width of the gap between the HSK tooling 60 and the tooling holder 70 is "D1".
- FIG. 7 shows how the HSK tooling 60 is abnormally attached to the tooling holding portion 70 .
- the width of the gap between the HSK tooling 60 and the tooling holding portion 70 is "D2".
- the gap width "D2" at the time of abnormal mounting is longer than the gap width "D1" at the time of normal mounting.
- the machine tool 100 determines whether the HSK tooling 60 is normally attached to the tooling holding portion 70 based on physical information indicating the state of the gap between the HSK tooling 60 and the tooling holding portion 70 .
- “Physical information” as used herein is a concept including any index that correlates with the width of the gap between the HSK tooling 60 and the tooling holder 70 .
- the physical information includes image information indicating the state of the gap between the HSK tooling 60 and the tooling holder 70 .
- the physical information includes distance information indicating the width of the gap between the HSK tooling 60 and the tooling holder 70 .
- the machine tool 100 executes a predetermined warning process. This allows the operator to notice that the HSK tooling 60 has been abnormally attached to the tooling holding portion 70 .
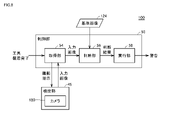
- FIG. 8 is a diagram showing an example of the functional configuration of the machine tool 100. As shown in FIG.
- the control unit 50 of the machine tool 100 includes an acquisition unit 54, a determination unit 56, and an execution unit 58 as functional configurations. These configurations will be described in order below.
- each functional configuration shown in FIG. 8 can be implemented in any unit that configures the control unit 50.
- part or all of the functional configuration shown in FIG. 8 is implemented in the aforementioned CPU unit 200 (see FIG. 2).
- part or all of the functional configuration shown in FIG. 8 is implemented in the above-described CNC unit 300 (see FIG. 2).
- part or all of the functional configuration shown in FIG. 8 is implemented in the information processing apparatus 400 (see FIG. 2) described above.
- part or all of the functional configuration shown in FIG. 8 is implemented in the operation panel 500 (see FIG. 1) described above.
- a part of the functional configuration shown in FIG. 8 may be implemented in an external device such as a server, or may be implemented in dedicated hardware.
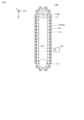
- FIG. 9 is a front view of the magazine 150.
- the acquisition unit 54 is implemented in the information processing device 400 (see FIG. 2).
- the acquisition unit 54 acquires physical information indicating the state of the gap between the HSK tooling 60 and the tooling holding unit 70 from the detection unit 45 while the HSK tooling 60 is attached to the tooling holding unit 70 .
- a camera 180 is shown in FIG. 8 as an example of the detection unit 45 .
- the acquisition unit 54 outputs a photographing instruction to the camera 180 at least one timing while the HSK tooling 60 is attached to the tooling holding unit 70 .
- the acquiring unit 54 acquires an input image 125 (see FIG. 10), which will be described later, representing the mounting portion of the HSK tooling 60 and the tooling holding unit 70 from the camera 180 as the physical information.
- the camera 180 is provided, for example, to photograph the magazine 150 inside the tool storage section 40A (see FIG. 1).
- Magazine 150 includes motor 112 M, drive sprocket 113 , driven sprocket 114 and endless chain 115 .
- the drive sprocket 113 is connected to the output shaft of the motor 112M (see FIG. 2).
- the drive sprocket 113 rotates when power is transmitted from the motor 112M.
- the endless chain 115 is stretched between a driving sprocket 113 and a driven sprocket 114.
- Motor 112M rotationally drives driving sprocket 113, whereby the power of motor 112M is transmitted to driven sprocket 114 via endless chain 115.
- driven sprocket 114 and endless chain 115 rotate in conjunction with drive sprocket 113 .
- the endless chain 115 is provided with a plurality of pots 70P.
- the pot 70P is an example of the above tooling holding portion 70 (see FIG. 6).
- One HSK tooling 60 may be attached to each of the pots 70P.
- Machine tool 100 can drive a designated tool to an arbitrary position by controlling motor 112M.
- the machine tool 100 drives the empty pot 70P in front of the above-described door D1 based on the operator calling the pot 70P. After that, the operator opens the door D1 and mounts the HSK tooling 60 on the empty pot 70P. After that, the worker closes the door D1.
- the acquisition unit 54 Based on the fact that the operator has attached the HSK tooling 60 to the pot 70P, the acquisition unit 54 outputs a photographing instruction to the camera 180 and acquires an input image 125, which will be described later, showing the portion where the HSK tooling 60 and the pot 70P are attached. get.
- the camera 180 is provided in the above-described tool storage section 40A (see FIG. 1) so that the gap between the HSK tooling 60 and the pot 70P is included in the field of view CR of the camera 180. Thereby, the camera 180 acquires image information indicating the state of the gap between the HSK tooling 60 and the pot 70P.
- a photographing instruction to the camera 180 is output at any timing while the HSK tooling 60 is attached to the tooling holding portion 70 .
- the photographing instruction is output at the timing when the operator attaches the HSK tooling 60 to the pot 70P.
- the door D1 (see FIG. 1) of the machine tool 100 is provided with an open/close sensor (not shown). After mounting the HSK tooling 60 on the pot 70P, the operator closes the door D1. Therefore, the acquisition unit 54 outputs a photographing instruction to the camera 180 based on the change in the output value of the opening/closing sensor from the value indicating the open state of the door D1 to the value indicating the closed state of the door D1.
- the machine tool 100 is provided with a tool attachment completion button (not shown).
- the camera 180 may be provided inside the processing machine body 40B.
- the control unit 50 drives the driving unit 130 described above to move the spindle 170 on which the HSK tooling 60 is mounted in front of the camera 180 .
- the main shaft 170 is an example of the above-described tooling holding portion 70 (see FIG. 6).
- the acquisition unit 54 outputs a photographing instruction to the camera 180 and acquires the input image 125 representing the mounting portion of the HSK tooling 60 and the tooling holding unit 70 .
- the camera 180 may be provided to photograph a tool post (not shown) inside the machine tool 100 .
- the tool post is an example of the above tooling holder 70 (see FIG. 6).
- the tool post has a turret.
- the turret is configured so that a plurality of HSK toolings 60 can be attached.
- the turret is configured to be pivotable, and pivots the HSK tooling 60 to a predetermined position when machining a workpiece.
- the control unit 50 moves the HSK tooling 60 in front of the camera 180 based on the fact that the HSK tooling 60 is attached to the tool post.
- the acquisition unit 54 outputs a photographing instruction to the camera 180 and acquires an input image 125 representing the mounting portion of the HSK tooling 60 and the tooling holding unit 70 .
- FIG. 10 is a conceptual diagram schematically showing the process of detecting a mounting abnormality of the HSK tooling 60.
- FIG. A reference image 124 and an input image 125 are shown in FIG.
- the determination unit 56 compares the input image 125 acquired by the acquisition unit 54 with the reference image 124 to determine whether the HSK tooling 60 is normally attached to the tooling holding unit 70 .
- the reference image 124 is an image obtained by photographing the HSK tooling 60 in advance when the HSK tooling 60 is normally attached to the tooling holding portion 70 .
- the reference image 124 is stored in advance in the storage device of the machine tool 100, for example.
- the determination unit 56 subtracts the reference image 124 from the input image 125 to generate the difference image 126 . Based on the difference image 126, the determination unit 56 determines whether the HSK tooling 60 is normally attached to the tooling holding unit 70 or not.
- the determining unit 56 assigns “0” (black) to pixels whose pixel values are equal to or less than the threshold th in the difference image 126, and assigns “0” (black) to pixels whose pixel values are greater than the threshold th in the difference image 126. Assign to "255" (white). Thereby, the determination unit 56 generates a binarized image from the difference image 126 . After that, the determination unit 56 counts the number of pixels having a pixel value of "0", and if the count value is equal to or greater than a predetermined value, the HSK tooling 60 is normally attached to the tooling holding unit 70. I judge. On the other hand, the determination unit 56 determines that the HSK tooling 60 is abnormally attached to the tooling holding unit 70 when the count value is smaller than the predetermined value.
- the judgment unit 56 does not necessarily need to use the reference image 124 when detecting the mounting abnormality of the HSK tooling 60 .
- Various image processing algorithms can be used for the detection process.
- the determination unit 56 detects a mounting abnormality of the HSK tooling 60 using the learned model.
- the trained model is generated in advance by learning processing using the training data set.
- the learning data set includes a plurality of learning images showing how the HSK tooling 60 and tooling holder 70 are mounted. Each learning image is associated with a label indicating whether the HSK tooling 60 is normally attached to the tooling holder 70 .
- the internal parameters of the trained model are optimized in advance by learning processing using such a learning data set.
- CNN convolutional neural network
- FCN full-layer convolutional neural network
- support vector machine etc.
- the determination unit 56 Based on the acquisition of the input image 125 from the camera 180, the determination unit 56 inputs the input image 125 into the learned model. As a result, the learned model outputs a probability indicating that the HSK tooling 60 is incorrectly worn. The determination unit 56 determines that the HSK tooling 60 is abnormally attached to the tooling holding unit 70 when the probability exceeds a predetermined value.
- execution unit 58 (E3. Execution unit 58) Next, functions of the execution unit 58 shown in FIG. 8 will be described.
- the execution unit 58 is implemented, for example, in the information processing device 400 described above or the operation panel 500 described above.
- the execution unit 58 executes predetermined warning processing when the determination unit 56 determines that the HSK tooling 60 is abnormally attached to the tooling holding unit 70 .
- the warning processing is processing for notifying the operator that the HSK tooling 60 has been abnormally attached to the tooling holding portion 70 .
- the execution unit 58 displays a warning on the display 505 of the operation panel 500 indicating that the HSK tooling 60 is abnormally mounted.
- the warning includes, for example, a message prompting the tooling holder 70 to remount the HSK tooling 60 by inverting it 180 degrees. As a result, the operator can easily grasp how the HSK tooling 60 should be reattached to the tooling holding portion 70 .
- the warning indicating the mounting abnormality is displayed on the display 505 of the operation panel 500
- the warning may be displayed on other display units.
- the output mode of the warning is not limited to display.
- the warning may be output as a sound such as a buzzer sound or voice.
- the warning may be sent to another device by e-mail or the like.
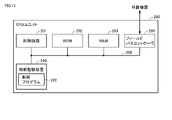
- FIG. 11 is a diagram showing an example of the hardware configuration of the CPU unit 200. As shown in FIG.
- the CPU unit 200 includes a control circuit 201 , a ROM (Read Only Memory) 202 , a RAM (Random Access Memory) 203 , a fieldbus controller 204 and an auxiliary storage device 220 . These components are connected to internal bus 209 .
- the control circuit 201 is composed of, for example, at least one integrated circuit.
- An integrated circuit is composed of, for example, at least one CPU, at least one GPU (Graphics Processing Unit), at least one ASIC (Application Specific Integrated Circuit), at least one FPGA (Field Programmable Gate Array), or a combination thereof can be
- the control circuit 201 controls the operation of the CPU unit 200 by executing various programs such as the control program 222 .
- the control circuit 201 reads the control program 222 from the auxiliary storage device 220 or the ROM 202 to the RAM 203 based on the reception of the instruction to execute the control program 222 .
- the RAM 203 functions as a working memory and temporarily stores various data necessary for executing the control program 222 .
- the fieldbus controller 204 is a communication unit for realizing communication with various units connected to the fieldbus.
- EtherCAT registered trademark
- EtherNet/IP registered trademark
- CC-Link registered trademark
- CompoNet registered trademark
- units connected to the field bus include the motor driver 111M, the ATC driver 121A, and the CNC unit 300 described above.
- the auxiliary storage device 220 is, for example, a storage medium such as a hard disk or flash memory.
- the auxiliary storage device 220 stores a control program 222 and the like.
- the storage location of the control program 222 is not limited to the auxiliary storage device 220, and may be stored in the storage area of the control circuit 201 (for example, cache memory), ROM 202, RAM 203, external equipment (for example, server), or the like. good.
- control program 222 may be provided not as a standalone program but as part of an arbitrary program. In this case, various processes according to the present embodiment are implemented in cooperation with arbitrary programs. Even a program that does not include such a part of modules does not deviate from the gist of control program 222 according to the present embodiment. Furthermore, some or all of the functions provided by control program 222 may be implemented by dedicated hardware. Furthermore, the CPU unit 200 may be configured in the form of a so-called cloud service in which at least one server executes part of the processing of the control program 222 .
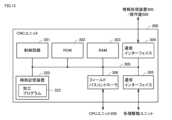
- FIG. 12 is a diagram showing an example of the hardware configuration of the CNC unit 300. As shown in FIG. 12
- the CNC unit 300 includes a control circuit 301, a ROM 302, a RAM 303, a communication interface 304, a communication interface 305, a fieldbus controller 306, and an auxiliary storage device 320. These components are connected to internal bus 309 .
- the control circuit 301 is composed of, for example, at least one integrated circuit.
- An integrated circuit may comprise, for example, at least one CPU, at least one ASIC, at least one FPGA, or a combination thereof.
- the control circuit 301 controls the operation of the CNC unit 300 by executing various programs such as the machining program 322 .
- the machining program 322 is a program for realizing workpiece machining.
- the control circuit 301 reads the machining program 322 from the ROM 302 to the RAM 303 based on the acceptance of the instruction to execute the machining program 322 .
- the RAM 303 functions as a working memory and temporarily stores various data necessary for executing the machining program 322 .
- a LAN, WLAN, Bluetooth (registered trademark), or the like is connected to the communication interface 304 .
- CNC unit 300 exchanges data with external devices via communication interface 304 .
- Examples of the external device include the information processing apparatus 400 described above, the operation panel 500 described above, a server (not shown), and the like.
- a communication interface 305 is an interface for realizing communication with an external device.
- CNC unit 300 exchanges data with external devices via communication interface 305 .
- the external device includes various drive units (for example, the motor drivers 131B, 131C, 131X to 131Z, etc. described above) for machining a workpiece.
- the fieldbus controller 306 is a communication unit for realizing communication with various units connected to the fieldbus.
- EtherCAT, EtherNet/IP, CC-Link, CompoNet, or the like is adopted as a field network communication standard.
- An example of a unit connected to the fieldbus is the CPU unit 200 or the like.
- the auxiliary storage device 320 is, for example, a storage medium such as a hard disk or flash memory.
- the auxiliary storage device 320 stores a machining program 322 and the like.
- the storage location of the machining program 322 is not limited to the auxiliary storage device 320, and may be stored in the storage area of the control circuit 301 (eg, cache memory), ROM 302, RAM 303, external device (eg, server), etc. good.
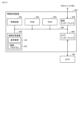
- FIG. 13 is a diagram showing an example of the hardware configuration of the information processing device 400. As shown in FIG. 13
- the information processing device 400 includes a control circuit 401 , a ROM 402 , a RAM 403 , a communication interface 404 , a camera interface 405 and an auxiliary storage device 420 . These components are connected to internal bus 409 .
- the control circuit 401 is composed of, for example, at least one integrated circuit.
- An integrated circuit may be comprised of, for example, at least one CPU, at least one GPU, at least one ASIC, at least one FPGA, or combinations thereof.
- the control circuit 401 controls the operation of the information processing device 400 by executing various programs such as a control program 422 for detecting mounting abnormalities of the HSK tooling 60 .
- the control circuit 401 reads a program to be executed from the auxiliary storage device 420 or the ROM 402 to the RAM 403 on the basis of receiving execution instructions for various programs.
- a RAM 403 functions as a working memory and temporarily stores various data necessary for program execution.
- the communication interface 404 is an interface for realizing communication using LAN, WLAN, Bluetooth, or the like.
- Information processing apparatus 400 exchanges data with external devices (for example, CNC unit 300 or a server) via communication interface 404 .
- the information processing device 400 may be configured such that the control program 422 can be downloaded via the communication interface 404 .
- a camera interface 405 is an interface for connecting to the camera 180 by wire or wirelessly.
- the camera 180 may be a CCD (Charge Coupled Device) camera, an infrared camera (thermography), or other types of cameras.
- CCD Charge Coupled Device
- thermography infrared camera
- the auxiliary storage device 420 is, for example, a storage medium such as a hard disk or flash memory.
- Auxiliary storage device 420 stores, for example, reference image 124 and control program 422 described above.
- the storage location of the reference image 124 and the control program 422 is not limited to the auxiliary storage device 420, but is stored in the storage area of the control circuit 401 (for example, cache memory), ROM 402, RAM 403, external equipment (for example, server), and the like. may be
- control program 422 may be provided as a part of an arbitrary program, not as a standalone program. In this case, processing according to the present embodiment is realized in cooperation with an arbitrary program. Even a program that does not include some of such modules does not deviate from the gist of machine tool 100 according to the present embodiment. Furthermore, part or all of the functions provided by control program 422 according to the present embodiment may be realized by dedicated hardware. Furthermore, machine tool 100 and a server may work together to realize the processing according to the present embodiment. Furthermore, information processing apparatus 400 may be configured in the form of a so-called cloud service in which at least one server implements processing according to the present embodiment.
- FIG. 14 is a diagram showing an example of the hardware configuration of the operation panel 500. As shown in FIG. 14,
- the operation panel 500 includes a control circuit 501, a ROM (Read Only Memory) 502, a RAM (Random Access Memory) 503, a communication interface 504, a display 505, operation keys 506, and an auxiliary storage device 520. These components are connected to internal bus 509 .
- the control circuit 501 is composed of, for example, at least one integrated circuit.
- An integrated circuit may be comprised of, for example, at least one CPU, at least one GPU, at least one ASIC, at least one FPGA, or combinations thereof.
- the control circuit 501 controls the operation of the operation panel 500 by executing various programs such as the control program 522 .
- Control program 522 defines commands for controlling operation panel 500 .
- the control circuit 501 reads the control program 522 from the auxiliary storage device 520 or the ROM 502 to the RAM 503 based on the reception of the instruction to execute the control program 522 .
- the RAM 503 functions as a working memory and temporarily stores various data necessary for executing the control program 522 .
- the communication interface 504 is a communication unit for realizing communication using a LAN (Local Area Network) cable, WLAN, Bluetooth, or the like.
- the operation panel 500 realizes communication with external devices such as the CNC unit 300 described above via the communication interface 504 .
- the display 505 is, for example, a liquid crystal display, an organic EL display, or other display device.
- the display 505 sends an image signal for displaying an image to the display 505 according to a command from the control circuit 501 or the like.
- the display 505 is configured by, for example, a touch panel, and receives various operations for the machine tool 100 by touch operations.
- the operation key 506 is composed of a plurality of hardware keys and accepts various user operations on the operation panel 500. A signal corresponding to the pressed key is output to the control circuit 501 .
- the auxiliary storage device 520 is, for example, a storage medium such as a hard disk or flash memory.
- Auxiliary storage device 520 stores a control program 522 and the like.
- the storage location of the control program 522 is not limited to the auxiliary storage device 520, and may be stored in the storage area of the control circuit 501 (for example, cache memory), ROM 502, RAM 503, external equipment (for example, server), or the like.
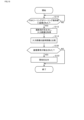
- FIG. 15 is a flow chart showing part of the processing executed by control unit 50 of machine tool 100 .
- the processing shown in FIG. 15 is implemented by the control unit 50 executing a control program (eg, the control program 422 or the control program 522 described above). In other aspects, part or all of the processing may be performed by circuit elements or other hardware.
- a control program eg, the control program 422 or the control program 522 described above.
- step S110 the control unit 50 determines whether the HSK tooling 60 is attached to the tooling holding unit 70. Whether or not the HSK tooling 60 is attached to the tooling holder 70 is determined by various methods.
- the door D1 (see FIG. 1) of the machine tool 100 is provided with an open/close sensor (not shown).
- the operator closes the door D1 when the mounting of the HSK tooling 60 to the tooling holding portion 70 is completed. Therefore, the control unit 50 determines that the HSK tooling 60 is attached to the tooling holding unit 70 based on the fact that the output value of the open/close sensor changes from the value indicating the open state of the door D1 to the value indicating the closed state of the door D1. I judge.
- the machine tool 100 is provided with an installation completion button (not shown).
- the operator presses the attachment completion button when the attachment of the HSK tooling 60 to the tooling holding portion 70 is completed. Therefore, the control unit 50 determines that the HSK tooling 60 is attached to the tooling holding unit 70 based on the pressing of the attachment completion button.
- control unit 50 determines that the HSK tooling 60 is attached to the tooling holding unit 70 (YES in step S110), it switches the control to step S112. Otherwise (NO in step S110), control unit 50 executes the process of step S110 again.
- step S112 the control unit 50 functions as the acquisition unit 54 (see FIG. 8) described above, and outputs a photographing instruction to the camera 180 described above. As a result, the control unit 50 acquires the above-described input image 125 (see FIG. 10) representing the mounting portion of the HSK tooling 60 and the tooling holding unit 70 .
- step S114 the control unit 50 compares the input image 125 acquired in step S112 with the reference image 124.
- the method of comparing the reference image 124 and the input image 125 is as described above with reference to FIG. 10 and the like, and thus description thereof will not be repeated.
- step S120 the control unit 50 functions as the determination unit 56 (see FIG. 8) described above, and determines whether the HSK tooling 60 is abnormally attached to the tooling holding unit 70 based on the comparison result in step S114. to decide.
- control unit 50 determines that HSK tooling 60 is abnormally attached to tooling holding unit 70 (YES in step S120)
- control is switched to step S122. Otherwise (NO in step S120), control unit 50 terminates the process shown in FIG.
- step S122 the control unit 50 functions as the above-described execution unit 58 (see FIG. 8) and executes a predetermined warning process.
- the control unit 50 displays a warning indicating that the HSK tooling 60 is incorrectly mounted on the display 505 of the operation panel 500 .
- the warning includes, for example, a message prompting the tooling holder 70 to remount the HSK tooling 60 by inverting it 180 degrees.
- the machine tool 100 detects the mounting abnormality of the HSK tooling 60 with respect to the tooling holding portion 70 by photographing the state of the gap between the HSK tooling 60 and the tooling holding portion 70 with the camera 180 .
- machine tool 100 according to the present modification uses a position sensor for detecting physical information correlated with the width of the gap between HSK tooling 60 and tooling holding portion 70 to detect the HSK tooling relative to tooling holding portion 70 . 60 is detected.
- the position sensor it is as described above, so the description other than that will not be repeated below.
- FIGS. 16 and 17 schematically show how the HSK tooling 60 is attached to the tooling holder 70.
- FIG. 16 and 17 schematically show how the HSK tooling 60 is attached to the tooling holder 70.
- the tooling holding portion 70 has an interlocking member 90 interlocking with the HSK shank 64 when the HSK shank 64 is inserted into the insertion port 75 .
- the interlocking member 90 is provided in the tooling holding portion 70 so as to be movable in the axial direction with respect to the central axis AX.
- Interlocking member 90 is, for example, a pin extending in the axial direction of central axis AX.
- a hole H is provided in the tooling holding portion 70 .
- the hole H extends in the axial direction of the central axis AX.
- the interlocking member 90 is provided in the tooling holding portion 70 so as to pass through the inside of the hole H. As shown in FIG.
- FIG. 16 shows how the HSK tooling 60 is normally attached to the tooling holding portion 70 .
- the groove portion 65A contacts the interlocking member 90 and the groove portion 65B contacts the engaging portion 75B.
- the interlocking member 90 is pushed in the insertion direction of the HSK tooling 60 (that is, the axial direction of the central axis AX) by the groove portion 65A.
- FIG. 17 shows how the HSK tooling 60 is attached to the tooling holder 70 abnormally.
- the groove portion 65A contacts the engaging portion 75B and the groove portion 65B contacts the interlocking member 90 .
- the interlocking member 90 is pushed in the insertion direction of the HSK tooling 60 (that is, the axial direction of the central axis AX) by the groove portion 65B.
- the amount of movement of the interlocking member 90 when the HSK tooling 60 is inserted into the tooling holding portion 70 correlates with the width of the gap between the HSK tooling 60 and the tooling holding portion 70 . Therefore, the amount of movement can be an index for determining whether or not the HSK tooling 60 is normally attached to the tooling holding portion 70 .
- the machine tool 100 uses the position sensor 190 to detect the amount of movement of the interlocking member 90 when the HSK tooling 60 is attached to the tooling holding portion 70 .
- the position sensor 190 detects the position of the interlocking member 90 as physical information indicating the state of the gap between the HSK tooling 60 and the tooling holding portion 70 .
- position sensor 190 is not particularly limited. Any sensor capable of distinguishing the position of the interlocking member 90 in at least two stages can be employed as the position sensor 190 .
- position sensor 190 is a non-contact proximity sensor capable of detecting the presence or absence of an object within its detectable range.
- the position sensor 190 may be a contact switch capable of detecting contact of the interlocking member 90 .
- the position sensor 190 may be a distance sensor capable of detecting the distance from itself to the interlocking member 90 .
- FIGS. 16 and 17 show a non-contact proximity sensor as an example of the position sensor 190.
- the position sensor 190 is provided in the tooling holding portion 70 so that the interlocking member 90 moves between the inside and outside of the detectable range of the position sensor 190 when the HSK tooling 60 is attached to the tooling holding portion 70 .
- the interlocking member 90 moves from outside the detectable range of the position sensor 190 to within the detectable range of the position sensor 190 .
- the interlocking member 90 does not move within the detectable range of the position sensor 190 .
- the machine tool 10 can detect the mounting abnormality of the HSK tooling 60 according to the output value of the position sensor 190 .
- FIG. 18 is a diagram showing an example of a functional configuration of machine tool 100 according to the modification.
- the control unit 50 of the machine tool 100 includes an acquisition unit 54A, a determination unit 56A, and an execution unit 58 as functional configurations.
- the functional configuration shown in FIG. 18 differs from the functional configuration shown in FIG. 8 in that it includes an acquisition unit 54A instead of the acquisition unit 54 and a determination unit 56A instead of the determination unit 56. different. Since the function of execution unit 58 is as described above, the description thereof will not be repeated below.
- (a) Acquisition unit 54A First, the function of the acquisition unit 54A shown in FIG. 18 will be described. As an example, the acquisition unit 54A is implemented in the information processing device 400 (see FIG. 2).
- the acquisition unit 54 acquires physical information indicating the state of the gap between the HSK tooling 60 and the tooling holding unit 70 from the detection unit 45 .
- FIG. 18 shows the position sensor 190 described above as an example of the detection unit 45 .
- the position sensor 190 detects a detection value indicating the state of the gap between the HSK tooling 60 and the tooling holder 70 as the physical information.
- the timing at which the acquisition unit 54A acquires the detection value of the position sensor 190 is arbitrary. Typically, the acquisition unit 54A acquires the detection value from the position sensor 190 based on the operator mounting the HSK tooling 60 on the tooling holding unit 70. FIG.
- the door D1 (see FIG. 1) of the machine tool 100 is provided with an open/close sensor (not shown).
- the operator closes the door D1 when the mounting of the HSK tooling 60 to the tooling holding portion 70 is completed. Therefore, the acquisition unit 54A acquires the detection value from the position sensor 190 based on the change in the output value of the opening/closing sensor from the value indicating the open state of the door D1 to the value indicating the closed state of the door D1.
- the machine tool 100 is provided with an installation completion button (not shown).
- determination section 56A (b) Determination section 56A Next, the function of the determination section 56A shown in FIG. 18 will be described. As an example, determination unit 56A is implemented in information processing device 400 (see FIG. 2).
- the determination portion 56A determines that the HSK tooling 60 is abnormally attached to the tooling holding portion 70. I judge.
- the algorithm for determining abnormal attachment by the determination unit 56A is designed according to the type of the position sensor 190.
- position sensor 190 is a proximity sensor that indicates the presence or absence of an object in binary.
- the output value of position sensor 190 being “0” indicates that interlocking member 90 is not present in front of position sensor 190 .
- the fact that the output value of the position sensor 190 is “1” indicates that the interlocking member 90 is present in front of the position sensor 190 .
- the determination portion 56A determines that the HSK tooling 60 is abnormally attached to the tooling holding portion 70. do.
- the determining portion 56A determines that the HSK tooling 60 is normally attached to the tooling holding portion 70. to decide.
- the position sensor 190 is a distance sensor that outputs the distance to an object.
- the fact that the output value of the position sensor 190 is equal to or greater than the predetermined value indicates that the interlocking member 90 does not exist in front of the position sensor 190 .
- the fact that the output value of the position sensor 190 is smaller than the predetermined value indicates that the interlocking member 90 is present in front of the position sensor 190 .
- the determination portion 56A determines that the HSK tooling 60 is abnormally attached to the tooling holding portion 70. do.
- the determining portion 56A determines that the HSK tooling 60 is normally attached to the tooling holding portion 70. to decide.
- the machine tool 100 acquires physical information indicating the state of the gap between the HSK tooling 60 and the tooling holding portion 70 from the detecting portion 45 while the HSK tooling 60 is attached to the tooling holding portion 70. do. Then, the machine tool 100 determines whether the HSK tooling 60 is normally attached to the tooling holding portion 70 based on the physical information. When it is determined that the HSK tooling 60 is not properly attached to the tooling holding portion 70, the machine tool 100 executes a predetermined warning process. This allows the operator to notice that the HSK tooling 60 has been abnormally attached to the tooling holding portion 70 .
Landscapes
- Engineering & Computer Science (AREA)
- Mechanical Engineering (AREA)
- Physics & Mathematics (AREA)
- Optics & Photonics (AREA)
- Automatic Tool Replacement In Machine Tools (AREA)
- Machine Tool Sensing Apparatuses (AREA)
- Gripping On Spindles (AREA)
- Numerical Control (AREA)
Abstract
Description
まず、図1を参照して、実施の形態に従う工作機械100について説明する。図1は、工作機械100の外観を示す図である。
次に、図2を参照して、工作機械100の各種構成について説明する。図2は、工作機械100の駆動機構の一例を示す図である。
次に、図3~図5を参照して、HSKツーリングの構造について説明する。図3は、HSKツーリング60を示す斜視図である。図4は、HSKツーリング60の側面を図3に示されるX軸方向から表わした図である。図5は、HSKツーリング60の断面を図3に示されるX軸方向から表わした図である。
次に、図6および図7を参照して、ツーリング保持部70に対するHSKツーリング60の装着態様について説明する。図6および図7は、ツーリング保持部70に対するHSKツーリング60の装着態様を概略的に示す図である。
」と溝部65Bの深さ「DB」との差は非常に小さいため、HSKツーリング60は、本来とは180度反転してツーリング保持部70に装着されてしまうことがある。
図8~図10を参照して、HSKツーリング60の装着異常を検出するための機能構成について説明する。図8は、工作機械100の機能構成の一例を示す図である。
まず、図9を参照して、図8に示される取得部54の機能について説明する。図9は、マガジン150を正面から示す図である。一例として、取得部54は、情報処理装置400(図2参照)に実装される。
次に、図10を参照して、図8に示される判断部56の機能について説明する。一例として、判断部56は、情報処理装置400(図2参照)に実装される。
次に、図8に示される実行部58の機能について説明する。実行部58は、たとえば、上述の情報処理装置400または上述の操作盤500に実装される。
図11を参照して、上述の図2に示されるCPUユニット200のハードウェア構成について説明する。図11は、CPUユニット200のハードウェア構成の一例を示す図である。
次に、図12を参照して、上述の図2に示されるCNCユニット300のハードウェア構成について説明する。図12は、CNCユニット300のハードウェア構成の一例を示す図である。
次に、図13を参照して、上述の図2に示される情報処理装置400のハードウェア構成について説明する。図13は、情報処理装置400のハードウェア構成の一例を示す図である。
次に、図14を参照して、上述の図2に示される操作盤500のハードウェア構成について説明する。図14は、操作盤500のハードウェア構成の一例を示す図である。
次に、図15を参照して、工作機械100の制御構造について説明する。図15は、工作機械100の制御部50が実行する処理の一部を表わすフローチャートである。
次に、HSKツーリング60の装着異常を検出する方法の変形例について説明する。
まず、図16および図17を参照して、ツーリング保持部70に対するHSKツーリング60の装着態様について説明する。図16および図17は、ツーリング保持部70に対するHSKツーリング60の装着態様を概略的に示す図である。
次に、図18を参照して、変形例に従う工作機械100の機能構成について説明する。図18は、変形例に従う工作機械100の機能構成の一例を示す図である。
まず、図18に示される取得部54Aの機能について説明する。一例として、取得部54Aは、情報処理装置400(図2参照)に実装される。
次に、図18に示される判断部56Aの機能について説明する。一例として、判断部56Aは、情報処理装置400(図2参照)に実装される。
以上のようにして、工作機械100は、HSKツーリング60がツーリング保持部70に装着されている間に、HSKツーリング60とツーリング保持部70との隙間の状態を示す物理情報を検出部45から取得する。そして、工作機械100は、当該物理情報に基づいて、HSKツーリング60がツーリング保持部70に正常に装着されているか否かを判断する。HSKツーリング60がツーリング保持部70に正常に装着されていないと判断された場合には、工作機械100は、予め定められた警告処理を実行する。これにより、作業者は、HSKツーリング60がツーリング保持部70に異常に装着されたことに気付くことができる。
Claims (9)
- 工作機械であって、
ツーリングの挿入口を有するツーリング保持部を備え、
前記ツーリングは、
工具を保持するための工具保持部と、
前記挿入口に挿入されるHSKシャンクとを含み、
前記工作機械は、さらに、
前記ツーリングと前記ツーリング保持部との隙間の状態を示す物理情報を検出するための検出部と、
前記工作機械を制御するための制御部とを備え、
前記制御部は、
前記ツーリングが前記ツーリング保持部に装着されている間に、前記検出部から前記物理情報を取得するための取得部と、
前記取得された物理情報に基づいて、前記ツーリング保持部に対する前記ツーリングの挿入方向を中心として前記ツーリングが前記ツーリング保持部に反転して装着されているか否かを判断するための判断部と、
前記ツーリングが前記ツーリング保持部に反転して装着されていると判断された場合に、予め定められた処理を実行するための実行部とを含む、工作機械。 - 前記検出部は、カメラを含み、
前記カメラは、前記隙間を表わす画像を前記物理情報として取得する、請求項1に記載の工作機械。 - 前記ツーリング保持部は、前記HSKシャンクが前記挿入口に挿入された際に当該HSKシャンクと連動する連動部材を含み、
前記検出部は、前記連動部材の位置を前記物理情報として検出するための位置センサを含む、請求項1または2に記載の工作機械。 - 前記HSKシャンクは、円筒部分を有し、
前記円筒部分は、
当該円筒部分の中心軸の方向において第1の深さを有する第1溝部と、
前記方向において第2の深さを有する第2溝部とを含み、
前記第2の深さは、前記第1の深さとは異なり、
前記ツーリング保持部は、
前記HSKシャンクが前記挿入口に挿入された際に前記第1溝部に係合する第1係合部と、
前記HSKシャンクが前記挿入口に挿入された際に前記第2溝部に係合する第2係合部とを含む、請求項1~3のいずれか1項に記載の工作機械。 - 前記判断部は、前記隙間の幅が所定値以上であることを前記物理情報が示す場合に、前記ツーリングが前記ツーリング保持部に反転して装着されていると判断する、請求項1~4のいずれか1項に記載の工作機械。
- 前記ツーリング保持部は、マガジンと、主軸と、刃物台との少なくとも1つを含む、請求項1~5のいずれか1項に記載の工作機械。
- 前記工作機械は、さらに、ディスプレイを備え、
前記予め定められた処理は、前記ツーリングの装着異常を示す警告を前記ディスプレイ
に表示する処理を含み、
前記警告は、前記ツーリング保持部に対して前記ツーリングを反転して装着し直すこと
を促すメッセージを含む、請求項1~6のいずれか1項に記載の工作機械。 - 工作機械の制御方法であって、
前記工作機械は、ツーリングの挿入口を有するツーリング保持部を備え、
前記ツーリングは、
工具を保持するための工具保持部と、
前記挿入口に挿入されるHSKシャンクとを含み、
前記工作機械は、さらに、前記ツーリングと前記ツーリング保持部との隙間の状態を示す物理情報を検出するための検出部を備え、
前記制御方法は、
前記ツーリングが前記ツーリング保持部に装着されている間に、前記検出部から前記物理情報を取得するステップと、
前記取得された物理情報に基づいて、前記ツーリング保持部に対する前記ツーリングの挿入方向を中心として前記ツーリングが前記ツーリング保持部に反転して装着されているか否かを判断するステップと、
前記ツーリングが前記ツーリング保持部に反転して装着されていると判断された場合に、予め定められた処理を実行するステップとを備える、制御方法。 - 工作機械の制御プログラムであって、
前記工作機械は、ツーリングの挿入口を有するツーリング保持部を備え、
前記ツーリングは、
工具を保持するための工具保持部と、
前記挿入口に挿入されるHSKシャンクとを含み、
前記工作機械は、さらに、前記ツーリングと前記ツーリング保持部との隙間の状態を示す物理情報を検出するための検出部を備え、
前記制御プログラムは、前記工作機械に、
前記ツーリングが前記ツーリング保持部に装着されている間に、前記検出部から前記物理情報を取得するステップと、
前記取得された物理情報に基づいて、前記ツーリング保持部に対する前記ツーリングの挿入方向を中心として前記ツーリングが前記ツーリング保持部に反転して装着されているか否かを判断するステップと、
前記ツーリングが前記ツーリング保持部に反転して装着されていると判断された場合に、予め定められた処理を実行するステップとを実行させる、制御プログラム。
Priority Applications (3)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| EP22872832.5A EP4406696A4 (en) | 2021-09-21 | 2022-09-16 | MACHINE TOOL, CONTROL METHOD AND CONTROL PROGRAM |
| US18/693,188 US20250001538A1 (en) | 2021-09-21 | 2022-09-16 | Machine tool, control method, and control program |
| CN202280063309.8A CN118076462A (zh) | 2021-09-21 | 2022-09-16 | 机床、控制方法以及控制程序 |
Applications Claiming Priority (2)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| JP2021-152818 | 2021-09-21 | ||
| JP2021152818A JP7055928B1 (ja) | 2021-09-21 | 2021-09-21 | 工作機械、制御方法、および制御プログラム |
Publications (1)
| Publication Number | Publication Date |
|---|---|
| WO2023048078A1 true WO2023048078A1 (ja) | 2023-03-30 |
Family
ID=81289271
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| PCT/JP2022/034708 Ceased WO2023048078A1 (ja) | 2021-09-21 | 2022-09-16 | 工作機械、制御方法、および制御プログラム |
Country Status (5)
| Country | Link |
|---|---|
| US (1) | US20250001538A1 (ja) |
| EP (1) | EP4406696A4 (ja) |
| JP (1) | JP7055928B1 (ja) |
| CN (1) | CN118076462A (ja) |
| WO (1) | WO2023048078A1 (ja) |
Families Citing this family (1)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JP7055928B1 (ja) * | 2021-09-21 | 2022-04-18 | Dmg森精機株式会社 | 工作機械、制御方法、および制御プログラム |
Citations (4)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JP2002331442A (ja) * | 2001-05-07 | 2002-11-19 | Yamazaki Mazak Corp | 工作機械のツールホルダの偏心検出装置 |
| JP2006315158A (ja) | 2005-05-16 | 2006-11-24 | Tokyo Seimitsu Co Ltd | 工作機械及びツールホルダの装着状態異常判定方法 |
| WO2016139726A1 (ja) * | 2015-03-02 | 2016-09-09 | 株式会社牧野フライス製作所 | 工具装着評価方法および工作機械 |
| JP6868147B1 (ja) * | 2020-08-04 | 2021-05-12 | Dmg森精機株式会社 | 工作機械、検知方法、および、検知プログラム |
Family Cites Families (7)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| DE4415306A1 (de) * | 1994-04-30 | 1995-11-02 | Chiron Werke Gmbh | Werkzeugmaschine |
| ITBO20010385A1 (it) * | 2001-06-18 | 2002-12-18 | Marposs Spa | Metodo e apparecchiatura per il controllo della posizione operativa di un utensile |
| DE10323593A1 (de) * | 2003-05-16 | 2004-12-09 | Chiron-Werke Gmbh & Co Kg | Werkzeugmaschine |
| US9205524B2 (en) * | 2009-01-16 | 2015-12-08 | John Wayne Stoneback | Test gauge |
| AT512250B1 (de) * | 2011-11-18 | 2013-11-15 | Anger Machining Gmbh | Werkzeugmaschine mit einer vielzahl feststehender werkzeugspindeln |
| US11660677B2 (en) * | 2018-05-30 | 2023-05-30 | Amera-Seiki Direct, Llc | Tooling assemblies for lathe machines, CNC threading lathes, and methods of milling threads in tubular workpieces |
| JP7055928B1 (ja) * | 2021-09-21 | 2022-04-18 | Dmg森精機株式会社 | 工作機械、制御方法、および制御プログラム |
-
2021
- 2021-09-21 JP JP2021152818A patent/JP7055928B1/ja not_active Expired - Fee Related
-
2022
- 2022-09-16 US US18/693,188 patent/US20250001538A1/en active Pending
- 2022-09-16 CN CN202280063309.8A patent/CN118076462A/zh not_active Withdrawn
- 2022-09-16 WO PCT/JP2022/034708 patent/WO2023048078A1/ja not_active Ceased
- 2022-09-16 EP EP22872832.5A patent/EP4406696A4/en not_active Withdrawn
Patent Citations (4)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JP2002331442A (ja) * | 2001-05-07 | 2002-11-19 | Yamazaki Mazak Corp | 工作機械のツールホルダの偏心検出装置 |
| JP2006315158A (ja) | 2005-05-16 | 2006-11-24 | Tokyo Seimitsu Co Ltd | 工作機械及びツールホルダの装着状態異常判定方法 |
| WO2016139726A1 (ja) * | 2015-03-02 | 2016-09-09 | 株式会社牧野フライス製作所 | 工具装着評価方法および工作機械 |
| JP6868147B1 (ja) * | 2020-08-04 | 2021-05-12 | Dmg森精機株式会社 | 工作機械、検知方法、および、検知プログラム |
Non-Patent Citations (1)
| Title |
|---|
| See also references of EP4406696A4 |
Also Published As
| Publication number | Publication date |
|---|---|
| JP7055928B1 (ja) | 2022-04-18 |
| EP4406696A4 (en) | 2025-01-01 |
| JP2023044778A (ja) | 2023-04-03 |
| CN118076462A (zh) | 2024-05-24 |
| EP4406696A1 (en) | 2024-07-31 |
| US20250001538A1 (en) | 2025-01-02 |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| KR102431825B1 (ko) | 공작기계 | |
| US10293499B2 (en) | Movable robot | |
| JP3923053B2 (ja) | ロボット教示装置 | |
| US10118295B2 (en) | Manual feed apparatus of robot for calculating operable range of robot | |
| JP6994411B2 (ja) | 工作機械システム | |
| JP7288367B2 (ja) | 工作機械システム | |
| US9227327B2 (en) | Robot system and method for operating robot system | |
| WO2021039829A1 (ja) | 生産システム | |
| KR102195024B1 (ko) | 비전카메라를 이용한 사출성형기용 취출 로봇 시스템 | |
| JP2019098479A (ja) | 工作機械 | |
| JP2002018680A (ja) | 工作機械 | |
| JP6709315B1 (ja) | 工作機械 | |
| KR20130074854A (ko) | 주조용 핸들링 로봇과 그 제어방법 | |
| JP7055928B1 (ja) | 工作機械、制御方法、および制御プログラム | |
| JP2022029120A (ja) | 工作機械、検知方法、および、検知プログラム | |
| JP2024034689A (ja) | 工作機械用ロボット、及び工作機械遠隔操作システム | |
| JP6832408B1 (ja) | 生産システム | |
| JP6784804B1 (ja) | 加工システム、工作機械、加工システムの制御方法、および、加工システムの制御プログラム | |
| JP7239393B2 (ja) | 工作機械、行動種別の判別方法、および、行動種別の判別プログラム | |
| WO2023042249A1 (ja) | 工作機械、制御方法、および制御プログラム | |
| JP7042939B1 (ja) | 工作機械、工作機械の制御方法、および工作機械の制御プログラム | |
| KR20220038984A (ko) | 로봇자동화를 위한 선반의 제어방법 | |
| JP7029491B2 (ja) | 工作機械、工作機械の制御方法、および工作機械の制御プログラム | |
| JP7038939B1 (ja) | 工作機械、工作機械の制御方法、および工作機械の制御プログラム | |
| Heimann et al. | Mobile Machine Tending with ROS2: Evaluation of system capabilities |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| 121 | Ep: the epo has been informed by wipo that ep was designated in this application |
Ref document number: 22872832 Country of ref document: EP Kind code of ref document: A1 |
|
| WWE | Wipo information: entry into national phase |
Ref document number: 18693188 Country of ref document: US Ref document number: 202280063309.8 Country of ref document: CN |
|
| WWE | Wipo information: entry into national phase |
Ref document number: 2022872832 Country of ref document: EP |
|
| NENP | Non-entry into the national phase |
Ref country code: DE |
|
| ENP | Entry into the national phase |
Ref document number: 2022872832 Country of ref document: EP Effective date: 20240422 |
|
| WWW | Wipo information: withdrawn in national office |
Ref document number: 2022872832 Country of ref document: EP |