WO2023068131A1 - 自律走行制御システム、自律走行制御装置、自律走行装置、自律走行制御方法、自律走行制御プログラム - Google Patents
自律走行制御システム、自律走行制御装置、自律走行装置、自律走行制御方法、自律走行制御プログラム Download PDFInfo
- Publication number
- WO2023068131A1 WO2023068131A1 PCT/JP2022/038020 JP2022038020W WO2023068131A1 WO 2023068131 A1 WO2023068131 A1 WO 2023068131A1 JP 2022038020 W JP2022038020 W JP 2022038020W WO 2023068131 A1 WO2023068131 A1 WO 2023068131A1
- Authority
- WO
- WIPO (PCT)
- Prior art keywords
- mode
- autonomous
- user operation
- operation mode
- switching
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Ceased
Links
Images





Classifications
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B60—VEHICLES IN GENERAL
- B60W—CONJOINT CONTROL OF VEHICLE SUB-UNITS OF DIFFERENT TYPE OR DIFFERENT FUNCTION; CONTROL SYSTEMS SPECIALLY ADAPTED FOR HYBRID VEHICLES; ROAD VEHICLE DRIVE CONTROL SYSTEMS FOR PURPOSES NOT RELATED TO THE CONTROL OF A PARTICULAR SUB-UNIT
- B60W60/00—Drive control systems specially adapted for autonomous road vehicles
- B60W60/001—Planning or execution of driving tasks
- B60W60/0025—Planning or execution of driving tasks specially adapted for specific operations
- B60W60/00256—Delivery operations
-
- G—PHYSICS
- G05—CONTROLLING; REGULATING
- G05D—SYSTEMS FOR CONTROLLING OR REGULATING NON-ELECTRIC VARIABLES
- G05D1/00—Control of position, course, altitude or attitude of land, water, air or space vehicles, e.g. using automatic pilots
- G05D1/20—Control system inputs
- G05D1/22—Command input arrangements
- G05D1/221—Remote-control arrangements
- G05D1/225—Remote-control arrangements operated by off-board computers
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B60—VEHICLES IN GENERAL
- B60W—CONJOINT CONTROL OF VEHICLE SUB-UNITS OF DIFFERENT TYPE OR DIFFERENT FUNCTION; CONTROL SYSTEMS SPECIALLY ADAPTED FOR HYBRID VEHICLES; ROAD VEHICLE DRIVE CONTROL SYSTEMS FOR PURPOSES NOT RELATED TO THE CONTROL OF A PARTICULAR SUB-UNIT
- B60W30/00—Purposes of road vehicle drive control systems not related to the control of a particular sub-unit, e.g. of systems using conjoint control of vehicle sub-units
- B60W30/18—Propelling the vehicle
- B60W30/182—Selecting between different operative modes, e.g. comfort and performance modes
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B60—VEHICLES IN GENERAL
- B60W—CONJOINT CONTROL OF VEHICLE SUB-UNITS OF DIFFERENT TYPE OR DIFFERENT FUNCTION; CONTROL SYSTEMS SPECIALLY ADAPTED FOR HYBRID VEHICLES; ROAD VEHICLE DRIVE CONTROL SYSTEMS FOR PURPOSES NOT RELATED TO THE CONTROL OF A PARTICULAR SUB-UNIT
- B60W50/00—Details of control systems for road vehicle drive control not related to the control of a particular sub-unit, e.g. process diagnostic or vehicle driver interfaces
- B60W50/02—Ensuring safety in case of control system failures, e.g. by diagnosing, circumventing or fixing failures
- B60W50/035—Bringing the control units into a predefined state, e.g. giving priority to particular actuators
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B60—VEHICLES IN GENERAL
- B60W—CONJOINT CONTROL OF VEHICLE SUB-UNITS OF DIFFERENT TYPE OR DIFFERENT FUNCTION; CONTROL SYSTEMS SPECIALLY ADAPTED FOR HYBRID VEHICLES; ROAD VEHICLE DRIVE CONTROL SYSTEMS FOR PURPOSES NOT RELATED TO THE CONTROL OF A PARTICULAR SUB-UNIT
- B60W50/00—Details of control systems for road vehicle drive control not related to the control of a particular sub-unit, e.g. process diagnostic or vehicle driver interfaces
- B60W50/08—Interaction between the driver and the control system
- B60W50/082—Selecting or switching between different modes of propelling
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B60—VEHICLES IN GENERAL
- B60W—CONJOINT CONTROL OF VEHICLE SUB-UNITS OF DIFFERENT TYPE OR DIFFERENT FUNCTION; CONTROL SYSTEMS SPECIALLY ADAPTED FOR HYBRID VEHICLES; ROAD VEHICLE DRIVE CONTROL SYSTEMS FOR PURPOSES NOT RELATED TO THE CONTROL OF A PARTICULAR SUB-UNIT
- B60W50/00—Details of control systems for road vehicle drive control not related to the control of a particular sub-unit, e.g. process diagnostic or vehicle driver interfaces
- B60W50/08—Interaction between the driver and the control system
- B60W50/14—Means for informing the driver, warning the driver or prompting a driver intervention
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B60—VEHICLES IN GENERAL
- B60W—CONJOINT CONTROL OF VEHICLE SUB-UNITS OF DIFFERENT TYPE OR DIFFERENT FUNCTION; CONTROL SYSTEMS SPECIALLY ADAPTED FOR HYBRID VEHICLES; ROAD VEHICLE DRIVE CONTROL SYSTEMS FOR PURPOSES NOT RELATED TO THE CONTROL OF A PARTICULAR SUB-UNIT
- B60W60/00—Drive control systems specially adapted for autonomous road vehicles
- B60W60/005—Handover processes
-
- G—PHYSICS
- G05—CONTROLLING; REGULATING
- G05D—SYSTEMS FOR CONTROLLING OR REGULATING NON-ELECTRIC VARIABLES
- G05D1/00—Control of position, course, altitude or attitude of land, water, air or space vehicles, e.g. using automatic pilots
- G05D1/20—Control system inputs
- G05D1/22—Command input arrangements
- G05D1/221—Remote-control arrangements
- G05D1/227—Handing over between remote control and on-board control; Handing over between remote control arrangements
-
- G—PHYSICS
- G05—CONTROLLING; REGULATING
- G05D—SYSTEMS FOR CONTROLLING OR REGULATING NON-ELECTRIC VARIABLES
- G05D1/00—Control of position, course, altitude or attitude of land, water, air or space vehicles, e.g. using automatic pilots
- G05D1/20—Control system inputs
- G05D1/22—Command input arrangements
- G05D1/228—Command input arrangements located on-board unmanned vehicles
-
- G—PHYSICS
- G08—SIGNALLING
- G08G—TRAFFIC CONTROL SYSTEMS
- G08G1/00—Traffic control systems for road vehicles
- G08G1/09—Arrangements for giving variable traffic instructions
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B60—VEHICLES IN GENERAL
- B60W—CONJOINT CONTROL OF VEHICLE SUB-UNITS OF DIFFERENT TYPE OR DIFFERENT FUNCTION; CONTROL SYSTEMS SPECIALLY ADAPTED FOR HYBRID VEHICLES; ROAD VEHICLE DRIVE CONTROL SYSTEMS FOR PURPOSES NOT RELATED TO THE CONTROL OF A PARTICULAR SUB-UNIT
- B60W2556/00—Input parameters relating to data
- B60W2556/45—External transmission of data to or from the vehicle
-
- G—PHYSICS
- G05—CONTROLLING; REGULATING
- G05D—SYSTEMS FOR CONTROLLING OR REGULATING NON-ELECTRIC VARIABLES
- G05D2105/00—Specific applications of the controlled vehicles
- G05D2105/20—Specific applications of the controlled vehicles for transportation
- G05D2105/28—Specific applications of the controlled vehicles for transportation of freight
- G05D2105/285—Specific applications of the controlled vehicles for transportation of freight postal packages
-
- G—PHYSICS
- G05—CONTROLLING; REGULATING
- G05D—SYSTEMS FOR CONTROLLING OR REGULATING NON-ELECTRIC VARIABLES
- G05D2107/00—Specific environments of the controlled vehicles
- G05D2107/10—Outdoor regulated spaces
-
- G—PHYSICS
- G05—CONTROLLING; REGULATING
- G05D—SYSTEMS FOR CONTROLLING OR REGULATING NON-ELECTRIC VARIABLES
- G05D2109/00—Types of controlled vehicles
- G05D2109/10—Land vehicles
Definitions
- the present disclosure relates to technology for controlling an autonomous mobile device capable of autonomous travel.
- Patent Document 1 discloses a traveling carriage that can be self-propelled by a motor. This traveling truck performs a self-propelled operation in which the drive wheels are driven to rotate by a motor, and a manual operation in which the drive wheels are brought into a brake-released state so that they can be operated by an external force.
- An object of the present disclosure is to provide an autonomous travel control system that allows the user to appropriately execute movement operations according to the situation. Another object of the present disclosure is to provide an autonomous travel control device that allows a user to appropriately perform a movement operation depending on the situation. Yet another object of the present disclosure is to provide an autonomous mobile device that allows a user to appropriately perform a movement operation depending on the situation. Yet another object of the present disclosure is to provide an autonomous travel control method that allows the user to appropriately perform a movement operation depending on the situation. Still another object of the present disclosure is to provide an autonomous travel control program that allows the user to appropriately execute a movement operation depending on the situation.
- a first aspect of the present disclosure is an autonomous traveling control system that has a processor and controls an autonomous traveling device capable of communicating with a center and capable of autonomous traveling,
- the processor executing an autonomous driving mode for executing autonomous driving; executing a stop mode that restricts movement of the autonomous mobile device; executing a user operation mode in which movement restrictions are released and a user's movement operation is accepted; Determining whether to allow switching of control modes including an autonomous driving mode, a stop mode, and a user operation mode; Detecting an external abnormality occurring outside the autonomous mobile device; is configured to run Determining whether to permit switching of the control mode allows switching from the stop mode to the user operation mode when permission is obtained from the center for switching from the stop mode to the user operation mode when no external abnormality is detected. and allowing switching from the stop mode to the user operation mode when an external anomaly is detected, even if permission has not been obtained.
- a second aspect of the present disclosure is an autonomous traveling control device that has a processor and controls an autonomous traveling device capable of communicating with a center and capable of autonomous traveling,
- the processor executing an autonomous driving mode for executing autonomous driving; executing a stop mode that restricts movement of the autonomous mobile device; executing a user operation mode in which movement restrictions are released and a user's movement operation is accepted; Determining whether to allow switching of control modes including an autonomous driving mode, a stop mode, and a user operation mode; Detecting an external abnormality occurring outside the autonomous mobile device; is configured to run Determining whether to permit switching of the control mode allows switching from the stop mode to the user operation mode when permission is obtained from the center for switching from the stop mode to the user operation mode when no external abnormality is detected. and allowing switching from the stop mode to the user operation mode when an external anomaly is detected, even if permission has not been obtained.
- a third aspect of the present disclosure is an autonomous mobile device having a processor, capable of communicating with a center and capable of autonomous travel,
- the processor executing an autonomous driving mode for executing autonomous driving; executing a stop mode that regulates movement; executing a user operation mode in which movement restrictions are released and a user's movement operation is accepted; Determining whether to allow switching of control modes including an autonomous driving mode, a stop mode, and a user operation mode; Detecting external anomalies occurring outside; is configured to run Determining whether to permit switching of the control mode allows switching from the stop mode to the user operation mode when permission is obtained from the center for switching from the stop mode to the user operation mode when no external abnormality is detected. and allowing switching from the stop mode to the user operation mode when an external anomaly is detected, even if permission has not been obtained.
- a fourth aspect of the present disclosure is an autonomous traveling control method executed by a processor to control an autonomous traveling device capable of communicating with a center and executing autonomous traveling, comprising: executing an autonomous driving mode for executing autonomous driving; executing a stop mode that restricts movement of the autonomous mobile device; executing a user operation mode in which movement restrictions are released and a user's movement operation is accepted; Determining whether to allow switching of control modes including an autonomous driving mode, a stop mode, and a user operation mode; Detecting an external abnormality occurring outside the autonomous mobile device; including Determining whether to permit switching of the control mode allows switching from the stop mode to the user operation mode when permission is obtained from the center for switching from the stop mode to the user operation mode when no external abnormality is detected. and allowing switching from the stop mode to the user operation mode when an external anomaly is detected, even if permission has not been obtained.
- a fifth aspect of the present disclosure is an autonomous running control program stored in a storage medium for controlling an autonomous running device capable of communicating with a center and capable of executing autonomous running, and containing instructions to be executed by a processor, the instruction is executing an autonomous driving mode for executing autonomous driving; executing a stop mode that restricts movement of the autonomous mobile device; releasing movement restrictions and executing a user operation mode in which a user's movement operation is accepted; Determining whether to allow switching of control modes including an autonomous driving mode, a stop mode, and a user operation mode; Detecting an external abnormality occurring outside the autonomous mobile device; including Judging whether to allow switching of the control mode allows switching from the stop mode to the user operation mode when permission is obtained from the center for switching from the stop mode to the user operation mode when an external abnormality is not detected. and allowing switching from the stop mode to the user operation mode when an external anomaly is detected, even if permission has not been obtained.
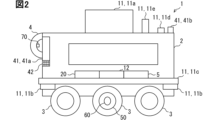
- FIG. 1 is a schematic diagram showing an autonomous mobile device to which a first embodiment is applied;
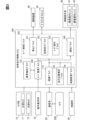
- FIG. 1 is a block diagram showing a functional configuration of an autonomous cruise control system according to a first embodiment;
- FIG. It is a flowchart which shows the process in autonomous driving mode among the autonomous driving control methods by 1st embodiment.
- It is a flowchart which shows the process in stop mode among the autonomous driving control methods by 1st embodiment.
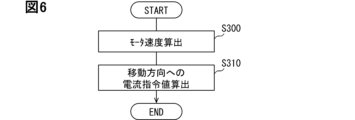
- 4 is a flowchart showing processing in a user operation mode of the autonomous travel control method according to the first embodiment;
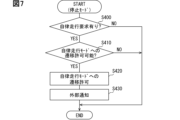
- It is a flowchart which shows the switching process from a stop mode to an autonomous driving mode among the autonomous driving control methods by 1st embodiment.
- FIG. 7 is a flowchart showing switching processing from a user operation mode to a stop mode in the autonomous travel control method according to the first embodiment;
- FIG. It is a flowchart which shows the switching process from autonomous driving mode to stop mode among the autonomous driving control methods by 1st embodiment.
- 4 is a flowchart showing a switching process from a stop mode to a user operation mode in the autonomous travel control method according to the first embodiment;
- It is a schematic diagram which shows the autonomous mobile device to which 2nd embodiment is applied.
- It is a block diagram which shows the functional structure of the autonomous driving control system by 2nd embodiment.
- the autonomous traveling control system 100 of the first embodiment shown in FIG. 1 controls traveling of the autonomous traveling device 1 shown in FIG.
- the autonomous mobile device 1 is, for example, a delivery robot that travels on roads and delivers packages.
- the operation of the autonomous mobile device 1 is managed through communication with an external center 200 .
- the autonomous mobile device 1 may be a physical distribution robot that transports packages in a warehouse that stores the packages.
- the autonomous mobile device 1 includes a vehicle body 2 having a space for storing luggage therein, and a plurality of driving wheels 3 provided on the vehicle body 2 .
- the body 2 is provided with a grip portion 4 .
- the grip part 4 is installed, for example, at the rear part of the vehicle body 2 .
- the grip part 4 is a grip gripped by a user who operates the autonomous mobile device 1 to move it.
- the autonomous mobile device 1 is a mobile body that travels using a battery 5 built into a vehicle body 2 as a drive source.
- the autonomous mobile device 1 includes a sensor system 10, a communication system 20, a map database (hereinafter referred to as "DB") 30, an information presentation system 40, a motor control unit 50, a regulation device 60, and an operation request switch 70 shown in FIG. is installed.
- the sensor system 10 acquires sensor information that can be used by the autonomous traveling control system 100 by detecting the external and internal worlds of the autonomous traveling device 1 .
- the sensor system 10 includes an external sensor 11 and an internal sensor 12 .
- the external sensor 11 acquires external world information that can be used by the autonomous driving control system 100 from the external environment that is the surrounding environment of the autonomous driving device 1 .
- the external world sensor 11 may acquire external world information by detecting a target existing in the external world of the autonomous mobile device 1 .
- the target detection type external sensor 11 includes an optical sensor 11a such as a camera and LiDAR (Light Detection and Ranging/Laser Imaging Detection and Ranging), and a sonar 11b.
- the target detection type external sensor 11 may include a radar. Further, the external sensor 11 may include a contact sensor 11c that detects contact with surrounding objects.
- the external sensor 11 may acquire external world information by monitoring the state of the external environment.
- the environment monitoring type external sensor 11 is an environment sensor 11e including at least one of a temperature sensor, a thermo camera, a wind sensor, and a water intrusion sensor.
- the external sensor 11 may include a positioning type sensor that acquires external world information by receiving positioning signals from satellites of the GNSS (Global Navigation Satellite System) that exist outside the autonomous mobile device 1.
- the positioning type external sensor 11 is, for example, a GNSS receiver 11d.
- the inner world sensor 12 acquires inner world information that can be used by the autonomous mobile control system 100 from the inner world that is the internal environment of the autonomous mobile device 1 .
- the inner world sensor 12 may acquire inner world information by detecting a specific motion physical quantity in the inner world of the autonomous mobile device 1 .
- the physical quantity sensing type internal sensor 12 is at least one of, for example, a running speed sensor, an acceleration sensor, a gyro sensor, and the like.
- the communication system 20 acquires communication information that can be used by the autonomous driving control system 100 by wireless communication.
- the communication system 20 may transmit and receive communication signals with a V2X system existing outside the autonomous mobile device 1 .
- the V2X type communication system 20 is, for example, at least one of a DSRC (Dedicated Short Range Communications) communication device, a cellular V2X (C-V2X) communication device, and the like. It can also be said that the V2X type communication system 20 is a sensor that acquires external world information through communication.
- the communication system 20 may transmit and receive communication signals to and from terminals existing in the inner world of the autonomous mobile device 1 .
- the terminal communication type communication system 20 is, for example, at least one of Bluetooth (registered trademark) equipment, Wi-Fi (registered trademark) equipment, infrared communication equipment, and the like.
- the map DB 30 stores map information that can be used by the autonomous driving control system 100.
- the map DB 30 includes at least one type of non-transitory tangible storage medium, such as semiconductor memory, magnetic medium, and optical medium.
- the map DB 30 may be a database of a locator that estimates the self-state quantity including the self-position of the autonomous mobile device 1 .
- the map DB 30 may be a database of a navigation unit that navigates the travel route of the autonomous mobile device 1 .
- the map DB 30 may be configured by combining a plurality of types of these databases.
- the map DB 30 acquires and stores the latest map information through communication with the external center 200 via the V2X type communication system 20, for example.
- the map information is two-dimensional or three-dimensional data as information representing the traveling environment of the autonomous mobile device 1 .
- the three-dimensional map data digital data of a high-precision map should be adopted.
- the map information may include road information representing at least one of the position, shape, road surface condition, and the like of the road itself.
- the map information may include sign information representing at least one of the position and shape of signs attached to roads and lane markings, for example.
- the map information may include structure information representing at least one of the positions and shapes of buildings facing roads and traffic lights, for example.
- the information presentation system 40 presents notification information to people around the autonomous mobile device 1 .
- the information presentation system 40 may be a visual presentation unit 41 that presents notification information by stimulating the vision of surrounding people.
- the visual presentation unit 41 may include, for example, a monitor device 41a that stimulates vision by displaying video or images, and a light emitting unit 41b that stimulates vision by emitting light from a lamp.
- the monitor device 41 a is provided, for example, at the rear portion of the vehicle body 2 and presents notification information to surrounding persons positioned behind the autonomous mobile device 1 .
- the monitor device 41a may allow a peripheral person to input information using a touch panel, operation buttons, or the like.
- the monitor device 41a may be capable of inputting an inquiry (to be described later) to the center 200 regarding transition to the user operation mode.
- the information presentation system 40 may be an auditory presentation unit 42 that presents notification information by stimulating the auditory sense of the occupant.
- the auditory presentation unit 42 is, for example, at least one type of speaker, buzzer, vibration unit, and the like.
- the information presentation system 40 may include a tactile presentation unit that presents notification information by stimulating the occupant's skin sensation.
- the skin sensation stimulated by the tactile sense presentation unit includes at least one of tactile sense, temperature sense, wind sense, and the like.
- the tactile sense presentation unit is, for example, a vibration unit or the like built in the grip portion 4 .
- the motor control unit 50 is a control unit that controls the drive motor that drives the drive wheels 3 to rotate.
- the motor control unit 50 is provided for each of the left and right drive wheels 3 and controls energization of the drive motor based on a control command (current command value) from the autonomous driving control system 100 .
- the regulation device 60 is a device that regulates movement of the autonomous mobile device 1 by an external force.
- the restricting device 60 has a so-called mechanical lock mechanism that mechanically restricts the rotation of the drive wheels 3 .
- the regulation device 60 is provided by an electromagnetic brake.
- the operation request switch 70 is a switch for requesting the autonomous mobile device 1, which is in a stopped state due to a stop mode described later, to switch to a user operation mode described later.
- the operation request switch 70 is provided on the grip portion 4 .
- the operation request switch 70 is operated by an arbitrary operator (user) among surrounding persons, and outputs an operation request for the autonomous mobile device 1 in the user operation mode to the autonomous mobile control system 100 .
- the operation request switch 70 may be, for example, a push button switch. Alternatively, the operation request switch 70 may be a toggle switch or a rocker switch.
- Autonomous driving control system 100 includes sensor system 10, communication system 20, map DB 30, information presentation system via at least one of LAN (Local Area Network) line, wire harness, internal bus, wireless communication line, etc. 40 , the motor control unit 50 , the regulation device 60 and the operation request switch 70 .
- the autonomous cruise control system 100 includes at least one dedicated computer.
- the dedicated computer that configures the autonomous driving control system 100 may be an operation control ECU (Electronic Control Unit) that controls the operation of the autonomous driving device 1 .
- a dedicated computer that configures the autonomous travel control system 100 may be a navigation ECU that navigates the travel route of the autonomous travel device 1 .
- a dedicated computer that configures the autonomous traveling control system 100 may be a locator ECU that estimates the self-state quantity of the autonomous traveling device 1 .
- the dedicated computer configuring the autonomous travel control system 100 may be an actuator ECU that controls the travel actuators of the autonomous travel device 1 .
- the dedicated computer that configures the autonomous traveling control system 100 may be an HCU (HMI (Human Machine Interface) Control Unit) that controls information presentation in the autonomous traveling device 1 .
- the dedicated computer that configures the autonomous driving control system 100 may be a computer other than the autonomous mobile device 1 that configures the center 200 or a mobile terminal that can communicate via the V2X type communication system 20, for example.
- a dedicated computer that constitutes the autonomous driving control system 100 has at least one memory 101 and at least one processor 102 .
- the memory 101 stores computer-readable programs, data, etc., non-temporarily, and includes at least one type of non-transitory storage medium such as a semiconductor memory, a magnetic medium, and an optical medium. tangible storage medium).
- Processor 102 is, for example, CPU (Central Processing Unit), GPU (Graphics Processing Unit), RISC (Reduced Instruction Set Computer)-CPU, DFP (Data Flow Processor), GSP (Graph Streaming Processor), etc. At least one type as a core.
- the processor 102 executes a plurality of instructions contained in the autonomous running control program stored in the memory 101 to control the behavior of the autonomous running device 1.
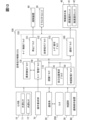
- the autonomous traveling control system 100 constructs a plurality of functional blocks for controlling the behavior of the autonomous traveling device 1 .
- the plurality of functional blocks constructed in the autonomous driving control system 100 include a recognition block 110, a self-position estimation block 120, a map distribution block 130, an abnormality detection block 135, a mode management block 140, and a mode control block. 150, and a notification block 160 are included.
- the recognition block 110 acquires detection information from multiple external sensors 11 .
- a recognition block 110 integrates a plurality of pieces of detection information and recognizes information about surrounding objects (peripheral object information).
- the peripheral object information includes, for example, the position and size of the peripheral object.
- the self-position estimation block 120 estimates the self-position of the autonomous mobile device 1 .
- the self-location estimation block 120 may estimate the self-location based on the positioning information of the GNSS receiver 11d.
- the self-position estimation block 120 may estimate the self-position by dead reckoning (dead reckoning/autonomous navigation) based on the detection information of the internal sensor 12 .
- the self-position estimation block 120 may estimate the self-position by matching the detection information of the external sensor 11 and the map information.
- the self-location estimation block 120 may combine the multiple self-location estimation techniques described above to estimate the self-location.
- the self-position estimation block 120 outputs the estimated self-position together with the traveling direction of the autonomous mobile device 1 and the traveling speed of the autonomous mobile device 1 .
- the map distribution block 130 extracts map information about the surroundings of the autonomous mobile device 1 from the map DB based on the estimated self-location.
- the anomaly detection block 135 detects external anomalies that occur outside the autonomous mobile device 1 .
- external anomalies include at least one of natural disasters such as flooding, strong winds, and earthquakes, and man-made disasters such as accidents and fires that occur outside the autonomous mobile device 1 .
- the mode management block 140 manages the control mode of the autonomous mobile device 1. Specifically, the mode management block 140 determines whether or not to allow control mode switching among the autonomous driving mode, the stop mode, and the user operation mode, and switches the control mode.
- Autonomous driving mode is a mode in which autonomous driving control is executed.
- autonomous travel mode autonomous travel to a destination given from the center 200 is carried out by controlling the drive motor.
- the stop mode is a mode that regulates the movement of the autonomous mobile device 1 due to an external force. Specifically, in the stop mode, the stop state is maintained at the stop point and mechanical movement is restricted by the restriction device 60 .
- the user operation mode is a mode that accepts movement operations by the user.
- the user is a person who wishes to move the autonomous mobile device 1 among those around the autonomous mobile device 1 .
- the locked state of the driving wheels 3 by the restricting device 60 is released.
- the autonomous mobile device 1 is caused to output a driving force according to the movement operation by the user.
- the driving force corresponding to the external force applied to the autonomous mobile device 1 by the user is output. That is, in the user operation mode, a driving force in a desired direction is output in response to an operation such as direct pushing or pulling of the autonomous mobile device 1 in a desired direction by the user.
- This user operation mode is an example of an "external force operation mode.”
- the mode management block 140 manages the control mode to be executed by appropriately switching the mode allowed by the autonomous mobile device 1 from among the above modes (details will be described later). In the following, switching of control modes may be referred to as transition of control modes.
- the mode control block 150 includes, as sub-blocks, a stop block 151 for executing the stop mode, an autonomous driving block 152 for executing the autonomous driving mode, and a user operation block 153 for executing the user operation mode.
- the notification block 160 executes various notifications while the autonomous mobile device 1 is running.
- the notification block 160 executes notification to people around the autonomous mobile device 1 via the information presentation system 40 .
- the notification block 160 executes notification to the center 200 via the V2X type communication system 20 . The details of the notification performed by notification block 160 will be described later.
- Each "S" in each processing flow below means a plurality of steps executed by a plurality of instructions included in the autonomous driving control program.
- the self-position estimation block 120 estimates the self-position of the autonomous mobile device 1 .
- the recognition block 110 acquires and integrates (sensor fusion) detection information from the plurality of external sensors 11, thereby recognizing surrounding object information.
- the map distribution block 130 extracts map information about the surroundings of the autonomous mobile device 1 from the map DB 30 based on the estimated self-location.
- the autonomous travel block 152 determines the travel route based on the surrounding object information, self-position, map information, and destination point.
- the autonomous travel block 152 determines a current command value so that the vehicle travels along the determined travel route, and outputs the command value to the motor control unit 50.
- FIG. By repeating the flow described above, the autonomous driving control system 100 executes autonomous driving to the destination point while sequentially updating the driving route.
- the stop block 151 calculates and outputs a current command value for continuing the stop at the stop position.
- the current command value is calculated based on Equation (1) below.
- the stop block 151 determines whether or not the conditions for stopping the autonomous mobile device 1 are satisfied.
- the stop condition is a condition for determining that the autonomous mobile device 1 has stopped.
- the stop condition is that the running speed is equal to or less than a threshold value (for example, 3 km/h) or continues for a predetermined time. If it is determined that the stop condition is not met, the flow returns to S200.
- the flow proceeds to S220.
- the stop block 151 outputs a mechanical lock request to the regulation device 60 . After the autonomous mobile device 1 is reliably stopped at the stop position by the processing in the stop mode described above, movement due to external force is restricted by the mechanical lock.
- the user operation block 153 calculates the rotational speed of the drive motor for the drive wheels 3.
- the user operation block 153 may calculate the rotation speed from the motor rotation speed detected by the rotation speed sensor installed on the drive motor.
- the user operation block 153 calculates and outputs a current command value (assist command value) in the moving direction due to the external force according to the rotational speed.
- the correspondence relationship with the rotation speed is defined in advance by a function, table, or the like.
- the assist command value may be determined according to the gradient of the road surface in addition to the rotational speed.
- the assist command value may include a current command value for outputting a driving force in a direction against a component of gravity parallel to the road surface.
- the mode management block 140 determines whether or not there is an autonomous travel request. An autonomous travel request is transmitted from the center 200 and acquired via the communication system 20 . If it is determined that there is no autonomous travel request, this flow ends and the stop mode continues. On the other hand, if it is determined that there is an autonomous travel request, the flow proceeds to S410.
- the mode management block 140 determines whether the transition to the autonomous driving mode can be permitted, that is, whether the transition can be permitted. For example, the mode management block 140 may determine that transition can be permitted when a stop condition in the stop mode is satisfied. Alternatively, the mode management block 140 may determine that the transition can be permitted when there is no external abnormality or when the abnormality is resolved. Alternatively, the mode management block 140 may determine that the transition can be permitted when there are no obstacles that impede travel. Note that if it is determined that the transition to the autonomous driving mode cannot be permitted, this flow ends and the stop mode continues. If it is determined that the transition can be permitted, the flow proceeds to S430.
- the mode management block 140 provides the autonomous driving block 152 with permission to transition to the autonomous driving mode.
- the notification block 160 notifies the start of the autonomous driving mode to the outside.
- the notification block 160 presents a voice message on the audio presentation unit 42 that notifies the start of driving and the attention call, such as "The vehicle is moving, please be careful.”
- Notification block 160 may visually present similar content in visual presentation unit 41 .
- the notification block 160 may notify the center 200 of information regarding the transition to the autonomous driving mode.
- the mode management block 140 determines whether or not the user's movement operation is continuing in the user operation mode. For example, the mode management block 140 may determine that the movement operation continues when a predetermined time has passed without the autonomous mobile device 1 being moved by an external force. Alternatively, the mode management block 140 may determine that the movement operation continues when the operation request switch 70 is on. If it is determined that the movement operation continues, this flow ends and the user operation mode continues. On the other hand, if it is determined that the movement operation is suspended, the flow proceeds to S510.
- the mode management block 140 provides the user operation block 153 with permission to transition to the user operation mode.
- the notification block 160 notifies the start of the user operation mode to the outside.
- the notification block 160 may perform notification similar to the notification in S430.
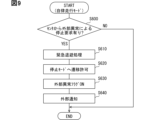
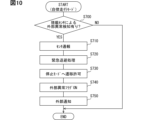
- FIG. 9 Each flow of FIG.9 and FIG.10 is repeatedly performed in parallel during execution of autonomous driving mode.
- the abnormality detection block 135 determines whether there is a stop request from the center 200 due to an external abnormality. If there is no stop request, this flow ends and the autonomous driving mode continues.
- the flow moves to S610.
- the autonomous driving block 152 executes emergency evacuation processing by autonomous driving. Specifically, in the emergency evacuation process, the autonomous travel block 152 determines a stop point and executes autonomous travel control so that the traveling speed becomes zero at that point.
- the emergency evacuation process can also be said to be a preparatory process for transitioning to a stop state in which movement in the stop mode is restricted.
- the mode management block 140 provides the stop block 151 with permission to transition to the stop mode.
- the abnormality detection block 135 sets the external abnormality flag to ON.
- the notification block 160 notifies the information related to the transition to the stop mode to the outside.
- the notification block 160 presents a voice message, such as "Stop, please move away", through the auditory presentation unit 42, notifying that the autonomous mobile device 1 is to be moved away from the autonomous mobile device 1.
- Notification block 160 may visually present similar content in visual presentation unit 41 .
- the notification block 160 may also notify the center 200 of information regarding the transition to the stop mode.
- the abnormality detection block 135 determines whether or not an external abnormality is detected by the external sensor 11 or the communication system 20, which is a sensor mounted on the autonomous mobile device 1, that is, whether or not detection information is acquired.
- external abnormality detection information includes external abnormality imaging information by a camera, abnormal temperature detection information by a thermometer or thermo camera, strong wind detection information by an anemometer, flood detection information by a flood sensor, and V2X type communication. It includes at least one kind of detection information of communication interruption with the center 200 by the system 20 . If the external abnormality detection information is not acquired, this flow ends and the autonomous driving mode continues.
- the flow proceeds to S710.
- the notification block 160 notifies the center 200 of the occurrence of an external abnormality.
- the subsequent processes of S720, S730, S740 and S750 are similar to the processes of S610, S620, S630 and S640 of FIG. 9, respectively, and the description of FIG. 9 is used.
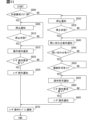
- the mode management block 140 determines whether the external abnormality flag is on or off. If it is determined that the external abnormality flag is set to ON, the process proceeds to S805.
- the notification block 160 executes a stop notification to notify the surroundings that the stop control is being performed in the stop mode. For example, the notification block 160 presents a voice message, such as “stop control is in progress, please leave”, through the auditory presentation unit 42 to notify that the stop control is being executed and that the autonomous mobile device 1 is to be distanced. Notification block 160 may visually present similar content in visual presentation unit 41 .
- the mode management block 140 determines whether or not the autonomous mobile device 1 has stopped in the stop mode. For example, the mode management block 140 may determine that the mechanical lock is stopped when the mechanical lock is activated. If it is determined that it is not in the stopped state, the flow returns to S805 to continue the stop notification.
- the notification block 160 executes an operation guidance notification that guides the user to perform an operation for transitioning to the user operation mode.
- the notification block 160 presents a voice message on the auditory presentation unit 42 that notifies how to transition to the user operation mode, such as "press the operation switch if you want to move the vehicle".
- Notification block 160 may visually present similar content in visual presentation unit 41 .
- the mode management block 140 determines whether or not an operation request from the user has been obtained. For example, the mode management block 140 determines that an operation request has been obtained when the operation request switch 70 is turned on. If it is determined that the operation request has not been acquired, the flow returns to S815 to continue the operation guidance notification.
- the notification block 160 executes user operation notification for notifying transition to the user operation mode.
- the notification block 160 presents a voice message on the auditory presentation unit 42 that notifies the start of movement and attention, such as "Be careful, the vehicle is moving."
- Notification block 160 may visually present similar content in visual presentation unit 41 .
- the notification block 160 may notify the attention by emitting light from the light emitting unit 41b.
- the notification block 160 notifies the center 200 of information regarding the transition to the user operation mode.
- the mode management block 140 allows transition to the user operation mode. When the process of S870 is completed, this flow ends and the process of FIG. 6 starts.
- the flow proceeds to S830.
- the notification block 160 executes a stop notification to notify the surroundings that the stop control is being performed in the stop mode.
- the mode management block 140 determines whether or not the autonomous mobile device 1 has stopped in the stop mode. If it is determined that the device is not in the stopped state, the flow returns to S830 to continue the stop notification.
- the notification block 160 executes an inquiry guidance notification that guides the user to perform an inquiry operation to the center 200 for transitioning to the user operation mode.
- the notification block 160 presents a voice message on the auditory presentation unit 42, such as "If you would like to move your vehicle, please contact the center.”
- Notification block 160 may visually present similar content in visual presentation unit 41 .
- the notification block 160 determines whether the query has been executed. If it is determined that the inquiry has not been executed, the flow returns to S840 to continue the inquiry guidance notification. On the other hand, if it is determined that the inquiry has been executed, the flow advances to S850.
- the mode management block 140 determines whether or not a transition permission, which is permission for switching from the stop mode to the user operation mode, has been obtained from the center 200. If it is not determined that the transition permission has been obtained, it waits until the transition permission is obtained. If it is determined that transition permission has been obtained, the flow advances to S855.
- a transition permission which is permission for switching from the stop mode to the user operation mode
- the notification block 160 executes an operation permission notification to guide the user that transition to the user operation mode is permitted.
- the notification block 160 presents a voice message, such as "Please press the permitted operation switch", through the auditory presentation unit 42 to notify that transition permission has been obtained and how to transition to the user operation mode.
- Notification block 160 may visually present similar content in visual presentation unit 41 .
- the mode management block 140 determines whether or not an operation request from the user has been obtained. If it is determined that the operation request has not been acquired, the flow returns to S855 to continue the operation permission notification.
- the flow proceeds to S865.
- the notification block 160 executes user operation notification for notifying transition to the user operation mode. After the process of S865 is executed, the flow shifts to S870.
- detecting an external anomaly includes obtaining a notification related to the occurrence of an external anomaly from the center 200 .
- an external abnormality can be reliably detected based on information from the center 200 .
- detecting an external abnormality includes acquiring detection information of the external abnormality from the sensors mounted on the autonomous mobile device 1 . As a result, it is possible to reliably detect an external abnormality without relying on information from the center 200 .
- the user is notified of information regarding switching from the stop mode to the user operation mode. Therefore, the user can appropriately grasp the state of the autonomous mobile device 1 .
- the second embodiment is a modification of the first embodiment.
- the user operation block 153 in the autonomous driving control system 100 of the second embodiment outputs driving force according to remote operation by the user in the user operation mode.
- remote operation the user inputs operation information to the remote control device 80 shown in FIGS.
- the remote control device 80 is a controller capable of inputting the traveling speed, traveling direction, etc. of the autonomous mobile device 1 .
- the remote control device 80 is housed in the vehicle body 2 of the autonomous mobile device 1, or is detachably attached to the vehicle body 2, and the user can arbitrarily take it out.
- the user operation mode in the second embodiment is an example of "remote operation mode".
- the user operation block 153 may be capable of selectively executing either the external force operation mode or the remote operation mode as the user operation mode.
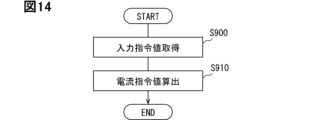
- the user operation block 153 When the remote operation mode is started as the user operation mode, the user operation block 153 first acquires the input command value input to the remote operation device 80 via the communication system 20 in S900. In subsequent S910, the user operation block 153 calculates and outputs a current command value according to the input command value. By repeating the flow described above, the autonomous traveling control system 100 executes traveling control of the autonomous traveling device 1 based on the user's remote control.
- the third embodiment is a modification of the first embodiment.
- the user operation block 153 in the third embodiment includes at least one of the external force operation mode and the remote operation mode, as well as a free mode in which the driving wheels 3 are mechanically locked and the driving force is lost.
- the user operation block 153 can appropriately select a mode to be executed from a plurality of sub-modes included in the user operation mode.
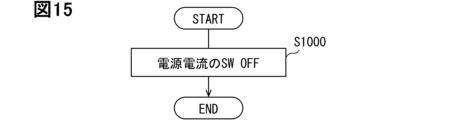
- the processing flow in free mode will be explained according to FIG.
- the free mode is started as the user operation mode
- the user operation block 153 turns off the power supply current switch for the drive motor.
- the autonomous driving control system 100 allows the user to move while allowing the driving force to disappear. Also, according to this flow, the inflow of the regenerated current due to the back electromotive force of the drive motor to the power supply can be cut off.
- the user operation block 153 may cause the motor control unit 50 to output a resistance force that prevents approaching the point when the autonomous mobile device 1 approaches a point that is an accessible distance away from surrounding objects.
- the resistance force can also be said to be a repulsive force acting in the direction opposite to the approaching direction to the surrounding object.
- the dedicated computer that configures the autonomous cruise control system 100 may have at least one of digital circuits and analog circuits as a processor.
- Digital circuits here include, for example, ASIC (Application Specific Integrated Circuit), FPGA (Field Programmable Gate Array), SOC (System on a Chip), PGA (Programmable Gate Array), and CPLD (Complex Programmable Logic Device). , at least one Such digital circuits may also have memory in which programs are stored.
- the autonomous cruise control system 100 may be implemented as an autonomous cruise control device that is a processing device (eg, a processing ECU, etc.) mounted on the autonomous mobile device 1. good.
- a processing device e.g, a processing ECU, etc.
- the above-described embodiments and variations may be implemented as a semiconductor device (for example, a semiconductor chip or the like) having at least one processor 102 and at least one memory 101 of the autonomous cruise control system 100 .
Landscapes
- Engineering & Computer Science (AREA)
- Automation & Control Theory (AREA)
- Transportation (AREA)
- Mechanical Engineering (AREA)
- Human Computer Interaction (AREA)
- General Physics & Mathematics (AREA)
- Physics & Mathematics (AREA)
- Aviation & Aerospace Engineering (AREA)
- Radar, Positioning & Navigation (AREA)
- Remote Sensing (AREA)
- Control Of Position, Course, Altitude, Or Attitude Of Moving Bodies (AREA)
- Control Of Driving Devices And Active Controlling Of Vehicle (AREA)
- Traffic Control Systems (AREA)
Abstract
Description
プロセッサは、
自律走行を実行する自律走行モードを実行することと、
自律走行装置の移動を規制する停止モードを実行することと、
移動の規制を解除してユーザによる移動操作を受け付けるユーザ操作モードを実行することと、
自律走行モード、停止モード及びユーザ操作モードを含む制御モードの切り替えの許否を判断することと、
自律走行装置の外部にて発生する外部異常を検知することと、
を実行するように構成され、
制御モードの切り替えの許否を判断することは、外部異常が検知されていない場合に、停止モードからユーザ操作モードへの切り替えに関するセンタからの許可を取得すると停止モードからユーザ操作モードへの切り替えを許容し、外部異常が検知された場合には、許可を取得していない場合でも停止モードからユーザ操作モードへの切り替えを許容することを含む。
プロセッサは、
自律走行を実行する自律走行モードを実行することと、
自律走行装置の移動を規制する停止モードを実行することと、
移動の規制を解除してユーザによる移動操作を受け付けるユーザ操作モードを実行することと、
自律走行モード、停止モード及びユーザ操作モードを含む制御モードの切り替えの許否を判断することと、
自律走行装置の外部にて発生する外部異常を検知することと、
を実行するように構成され、
制御モードの切り替えの許否を判断することは、外部異常が検知されていない場合に、停止モードからユーザ操作モードへの切り替えに関するセンタからの許可を取得すると停止モードからユーザ操作モードへの切り替えを許容し、外部異常が検知された場合には、許可を取得していない場合でも停止モードからユーザ操作モードへの切り替えを許容することを含む。
プロセッサは、
自律走行を実行する自律走行モードを実行することと、
移動を規制する停止モードを実行することと、
移動の規制を解除してユーザによる移動操作を受け付けるユーザ操作モードを実行することと、
自律走行モード、停止モード及びユーザ操作モードを含む制御モードの切り替えの許否を判断することと、
外部にて発生する外部異常を検知することと、
を実行するように構成され、
制御モードの切り替えの許否を判断することは、外部異常が検知されていない場合に、停止モードからユーザ操作モードへの切り替えに関するセンタからの許可を取得すると停止モードからユーザ操作モードへの切り替えを許容し、外部異常が検知された場合には、許可を取得していない場合でも停止モードからユーザ操作モードへの切り替えを許容することを含む。
自律走行を実行する自律走行モードを実行することと、
自律走行装置の移動を規制する停止モードを実行することと、
移動の規制を解除してユーザによる移動操作を受け付けるユーザ操作モードを実行することと、
自律走行モード、停止モード及びユーザ操作モードを含む制御モードの切り替えの許否を判断することと、
自律走行装置の外部にて発生する外部異常を検知することと、
を含み、
制御モードの切り替えの許否を判断することは、外部異常が検知されていない場合に、停止モードからユーザ操作モードへの切り替えに関するセンタからの許可を取得すると停止モードからユーザ操作モードへの切り替えを許容し、外部異常が検知された場合には、許可を取得していない場合でも停止モードからユーザ操作モードへの切り替えを許容することを含む。
命令は、
自律走行を実行する自律走行モードを実行させることと、
自律走行装置の移動を規制する停止モードを実行させることと、
移動の規制を解除してユーザによる移動操作を受け付けるユーザ操作モードを実行させることと、
自律走行モード、停止モード及びユーザ操作モードを含む制御モードの切り替えの許否を判断させることと、
自律走行装置の外部にて発生する外部異常を検知させることと、
を含み、
制御モードの切り替えの許否を判断させることは、外部異常が検知されていない場合に、停止モードからユーザ操作モードへの切り替えに関するセンタからの許可を取得すると停止モードからユーザ操作モードへの切り替えを許容させ、外部異常が検知された場合には、許可を取得していない場合でも停止モードからユーザ操作モードへの切り替えを許容させることを含む。
図1に示す第一実施形態の自律走行制御システム100は、図2に示す自律走行装置1の走行を制御する。自律走行装置1は、例えば、道路を走行して荷物を宅配する宅配ロボットである。自律走行装置1は、外部のセンタ200との通信により、その運行を管理される。尚、自律走行装置1は、荷物を保管する倉庫にて当該荷物を運搬する物流ロボットであってもよい。
(数1)
電流指令値=-C×モータ回転数-k×停止位置までの距離 ・・・(1)
図12~14に示すように第二実施形態は、第一実施形態の変形例である。
図15に示すように第三実施形態は、第一実施形態の変形例である。第三実施形態におけるユーザ操作ブロック153は、外力操作モード及び遠隔操作モードの少なくとも一方に加え、駆動輪3のメカロック状態を解除し、且つ駆動力を消失させるフリーモードを、ユーザ操作モードに含む。ユーザ操作ブロック153は、ユーザ操作モードに含まれる以上の複数のサブモードの中から、実行するモードを適宜選択可能である。
以上、複数の実施形態について説明したが、本開示は、当該説明の実施形態に限定して解釈されるものではなく、本開示の要旨を逸脱しない範囲内において種々の実施形態に適用することができる。
Claims (8)
- プロセッサ(102)を有し、センタ(200)と通信可能であって自律走行を実行可能な自律走行装置(1)を制御する自律走行制御システムであって、
前記プロセッサは、
前記自律走行を実行する自律走行モードを実行することと、
前記自律走行装置の移動を規制する停止モードを実行することと、
移動の規制を解除してユーザによる移動操作を受け付けるユーザ操作モードを実行することと、
前記自律走行モード、前記停止モード及び前記ユーザ操作モードを含む制御モードの切り替えの許否を判断することと、
前記自律走行装置の外部にて発生する外部異常を検知することと、
を実行するように構成され、
前記制御モードの切り替えの許否を判断することは、前記外部異常が検知されていない場合に、前記停止モードから前記ユーザ操作モードへの切り替えに関する前記センタからの許可を取得すると前記停止モードから前記ユーザ操作モードへの切り替えを許容し、前記外部異常が検知された場合には、前記許可を取得していない場合でも前記停止モードから前記ユーザ操作モードへの切り替えを許容することを含む自律走行制御システム。 - 前記外部異常を検知することは、前記センタから前記外部異常の発生に関連する通知を取得することを含む請求項1に記載の自律走行制御システム。
- 前記外部異常を検知することは、前記自律走行装置の搭載センサから前記外部異常の検出情報を取得することを含む請求項1又は請求項2に記載の自律走行制御システム。
- 前記停止モードから前記ユーザ操作モードへの切り替えに関する情報を前記ユーザに通知することをさらに実行するように構成される請求項1から請求項3のいずれか1項に記載の自律走行制御システム。
- プロセッサ(102)を有し、センタ(200)と通信可能であって自律走行を実行可能な自律走行装置(1)を制御する自律走行制御装置であって、
前記プロセッサは、
前記自律走行を実行する自律走行モードを実行することと、
前記自律走行装置の移動を規制する停止モードを実行することと、
移動の規制を解除してユーザによる移動操作を受け付けるユーザ操作モードを実行することと、
前記自律走行モード、前記停止モード及び前記ユーザ操作モードを含む制御モードの切り替えの許否を判断することと、
前記自律走行装置の外部にて発生する外部異常を検知することと、
を実行するように構成され、
前記制御モードの切り替えの許否を判断することは、前記外部異常が検知されていない場合に、前記停止モードから前記ユーザ操作モードへの切り替えに関する前記センタからの許可を取得すると前記停止モードから前記ユーザ操作モードへの切り替えを許容し、前記外部異常が検知された場合には、前記許可を取得していない場合でも前記停止モードから前記ユーザ操作モードへの切り替えを許容することを含む自律走行制御装置。 - プロセッサ(102)を有し、センタ(200)と通信可能であって自律走行を実行可能な自律走行装置であって、
前記プロセッサは、
前記自律走行を実行する自律走行モードを実行することと、
移動を規制する停止モードを実行することと、
移動の規制を解除してユーザによる移動操作を受け付けるユーザ操作モードを実行することと、
前記自律走行モード、前記停止モード及び前記ユーザ操作モードを含む制御モードの切り替えの許否を判断することと、
外部にて発生する外部異常を検知することと、
を実行するように構成され、
前記制御モードの切り替えの許否を判断することは、前記外部異常が検知されていない場合に、前記停止モードから前記ユーザ操作モードへの切り替えに関する前記センタからの許可を取得すると前記停止モードから前記ユーザ操作モードへの切り替えを許容し、前記外部異常が検知された場合には、前記許可を取得していない場合でも前記停止モードから前記ユーザ操作モードへの切り替えを許容することを含む自律走行装置。 - センタ(200)と通信可能であって自律走行を実行可能な自律走行装置(1)を制御するために、プロセッサ(102)により実行される自律走行制御方法であって、
前記自律走行を実行する自律走行モードを実行することと、
前記自律走行装置の移動を規制する停止モードを実行することと、
移動の規制を解除してユーザによる移動操作を受け付けるユーザ操作モードを実行することと、
前記自律走行モード、前記停止モード及び前記ユーザ操作モードを含む制御モードの切り替えの許否を判断することと、
前記自律走行装置の外部にて発生する外部異常を検知することと、
を含み、
前記制御モードの切り替えの許否を判断することは、前記外部異常が検知されていない場合に、前記停止モードから前記ユーザ操作モードへの切り替えに関する前記センタからの許可を取得すると前記停止モードから前記ユーザ操作モードへの切り替えを許容し、前記外部異常が検知された場合には、前記許可を取得していない場合でも前記停止モードから前記ユーザ操作モードへの切り替えを許容することを含む自律走行制御方法。 - センタ(200)と通信可能であって自律走行を実行可能な自律走行装置(1)を制御するために記憶媒体(101)に記憶され、プロセッサ(102)に実行させる命令を含む自律走行制御プログラムであって、
前記命令は、
前記自律走行を実行する自律走行モードを実行させることと、
前記自律走行装置の移動を規制する停止モードを実行させることと、
移動の規制を解除してユーザによる移動操作を受け付けるユーザ操作モードを実行させることと、
前記自律走行モード、前記停止モード及び前記ユーザ操作モードを含む制御モードの切り替えの許否を判断させることと、
前記自律走行装置の外部にて発生する外部異常を検知させることと、
を含み、
前記制御モードの切り替えの許否を判断させることは、前記外部異常が検知されていない場合に、前記停止モードから前記ユーザ操作モードへの切り替えに関する前記センタからの許可を取得すると前記停止モードから前記ユーザ操作モードへの切り替えを許容させ、前記外部異常が検知された場合には、前記許可を取得していない場合でも前記停止モードから前記ユーザ操作モードへの切り替えを許容させることを含む自律走行制御プログラム。
Priority Applications (3)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| CN202280069907.6A CN118103271A (zh) | 2021-10-19 | 2022-10-12 | 自主行驶控制系统、自主行驶控制装置、自主行驶装置、自主行驶控制方法、自主行驶控制程序 |
| EP22883435.4A EP4421580B1 (en) | 2021-10-19 | 2022-10-12 | Autonomous travel control system, autonomous travel control device, autonomous travel device, autonomous travel control method, autonomous travel control program |
| US18/637,662 US12509121B2 (en) | 2021-10-19 | 2024-04-17 | Autonomous travel control system, autonomous travel control device, autonomous travel device, autonomous travel control method, and non-transitory computer readable medium |
Applications Claiming Priority (2)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| JP2021171204A JP7619232B2 (ja) | 2021-10-19 | 2021-10-19 | 自律走行制御システム、自律走行制御装置、自律走行装置、自律走行制御方法、自律走行制御プログラム |
| JP2021-171204 | 2021-10-19 |
Related Child Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| US18/637,662 Continuation US12509121B2 (en) | 2021-10-19 | 2024-04-17 | Autonomous travel control system, autonomous travel control device, autonomous travel device, autonomous travel control method, and non-transitory computer readable medium |
Publications (1)
| Publication Number | Publication Date |
|---|---|
| WO2023068131A1 true WO2023068131A1 (ja) | 2023-04-27 |
Family
ID=86058243
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| PCT/JP2022/038020 Ceased WO2023068131A1 (ja) | 2021-10-19 | 2022-10-12 | 自律走行制御システム、自律走行制御装置、自律走行装置、自律走行制御方法、自律走行制御プログラム |
Country Status (5)
| Country | Link |
|---|---|
| US (1) | US12509121B2 (ja) |
| EP (1) | EP4421580B1 (ja) |
| JP (1) | JP7619232B2 (ja) |
| CN (1) | CN118103271A (ja) |
| WO (1) | WO2023068131A1 (ja) |
Cited By (1)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| US12510904B2 (en) * | 2022-12-28 | 2025-12-30 | Honda Motor Co., Ltd. | Driving assistance method, processing apparatus, and mobile machine |
Families Citing this family (1)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| US20250263086A1 (en) * | 2024-02-20 | 2025-08-21 | Toyota Jidosha Kabushiki Kaisha | Hardware-in-the-loop test bed with dual cockpit for autonomous vehicles |
Citations (3)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| WO2020031828A1 (ja) * | 2018-08-09 | 2020-02-13 | 本田技研工業株式会社 | 運転評価装置 |
| WO2020059189A1 (ja) | 2018-09-21 | 2020-03-26 | 日本精工株式会社 | 駆動輪、台車及び機器 |
| JP2021009433A (ja) * | 2019-06-28 | 2021-01-28 | トヨタ自動車株式会社 | 自動運転車両 |
Family Cites Families (13)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| DE102006051961A1 (de) * | 2006-11-03 | 2008-05-15 | Robert Bosch Gmbh | Vorrichtung zur Abstandsregelung eines Kraftfahrzeugs |
| JP5297935B2 (ja) * | 2009-08-07 | 2013-09-25 | 本田技研工業株式会社 | 車両の走行安全装置 |
| WO2011142447A1 (ja) | 2010-05-13 | 2011-11-17 | 株式会社小松製作所 | 建設機械の旋回駐車ブレーキ制御装置 |
| JP5783034B2 (ja) * | 2011-12-28 | 2015-09-24 | 株式会社デンソー | 車両用認証装置 |
| US20130218603A1 (en) * | 2012-02-21 | 2013-08-22 | Elwha Llc | Systems and methods for insurance based upon characteristics of a collision detection system |
| US9849882B2 (en) * | 2015-02-06 | 2017-12-26 | Jung H BYUN | Vehicle control based on crowdsourcing data |
| US10890909B2 (en) * | 2018-01-09 | 2021-01-12 | International Business Machines Corporation | Automobile driving mode determination |
| JP6628818B2 (ja) * | 2018-01-15 | 2020-01-15 | 本田技研工業株式会社 | 車両走行制御装置 |
| DE102019002787B4 (de) * | 2019-04-16 | 2024-09-19 | Daimler Truck AG | Verfahren und Vorrichtung zum automatisierten Notstoppen |
| KR102667038B1 (ko) * | 2019-07-11 | 2024-05-17 | 엘지전자 주식회사 | 에너지 소모 제어 장치 및 방법 |
| JP7124801B2 (ja) * | 2019-07-16 | 2022-08-24 | トヨタ自動車株式会社 | 車両制御装置 |
| JP7647489B2 (ja) | 2021-10-19 | 2025-03-18 | 株式会社デンソー | 自律走行制御システム、自律走行制御装置、自律走行装置、自律走行制御方法、自律走行制御プログラム |
| JP7647488B2 (ja) | 2021-10-19 | 2025-03-18 | 株式会社デンソー | 自律走行制御システム、自律走行制御装置、自律走行装置、自律走行制御方法、自律走行制御プログラム |
-
2021
- 2021-10-19 JP JP2021171204A patent/JP7619232B2/ja active Active
-
2022
- 2022-10-12 EP EP22883435.4A patent/EP4421580B1/en active Active
- 2022-10-12 CN CN202280069907.6A patent/CN118103271A/zh active Pending
- 2022-10-12 WO PCT/JP2022/038020 patent/WO2023068131A1/ja not_active Ceased
-
2024
- 2024-04-17 US US18/637,662 patent/US12509121B2/en active Active
Patent Citations (3)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| WO2020031828A1 (ja) * | 2018-08-09 | 2020-02-13 | 本田技研工業株式会社 | 運転評価装置 |
| WO2020059189A1 (ja) | 2018-09-21 | 2020-03-26 | 日本精工株式会社 | 駆動輪、台車及び機器 |
| JP2021009433A (ja) * | 2019-06-28 | 2021-01-28 | トヨタ自動車株式会社 | 自動運転車両 |
Non-Patent Citations (1)
| Title |
|---|
| See also references of EP4421580A4 |
Cited By (1)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| US12510904B2 (en) * | 2022-12-28 | 2025-12-30 | Honda Motor Co., Ltd. | Driving assistance method, processing apparatus, and mobile machine |
Also Published As
| Publication number | Publication date |
|---|---|
| CN118103271A (zh) | 2024-05-28 |
| US20250296601A1 (en) | 2025-09-25 |
| EP4421580A1 (en) | 2024-08-28 |
| US12509121B2 (en) | 2025-12-30 |
| EP4421580B1 (en) | 2026-05-06 |
| JP7619232B2 (ja) | 2025-01-22 |
| JP2023061291A (ja) | 2023-05-01 |
| EP4421580A4 (en) | 2025-01-22 |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| EP3503068B1 (en) | Vehicle and control method | |
| US20200333790A1 (en) | Control device, and control method, program, and mobile body | |
| JP7371629B2 (ja) | 情報処理装置、情報処理方法、プログラム、及び、車両 | |
| CN110023168B (zh) | 车辆控制系统、车辆控制方法及车辆控制程序 | |
| JP6544320B2 (ja) | 自動運転車両の制御システム及び制御方法 | |
| US20190004524A1 (en) | System and method for planning a vehicle path | |
| US11493359B2 (en) | Control device, control method, and mobile object | |
| JP2018077649A (ja) | 遠隔運転制御装置、車両制御システム、遠隔運転制御方法、および遠隔運転制御プログラム | |
| CN107614344A (zh) | 车辆控制装置 | |
| US12509121B2 (en) | Autonomous travel control system, autonomous travel control device, autonomous travel device, autonomous travel control method, and non-transitory computer readable medium | |
| JP2010282568A (ja) | 自律型移動体とこれを用いた移動体システム | |
| CN107122702A (zh) | 安全装置和安全方法 | |
| JP7798629B2 (ja) | 移動体の制御装置、移動体の制御方法、移動体、情報処理方法及びプログラム | |
| WO2023068132A1 (ja) | 自律走行制御システム、自律走行制御装置、自律走行装置、自律走行制御方法、自律走行制御プログラム | |
| JP2011048565A (ja) | 半自律型無人車両の遠隔操縦システム | |
| JP5024896B2 (ja) | 移動ロボットの操縦システム | |
| US20200234596A1 (en) | Method and apparatus for haptically guiding a user | |
| JP7647488B2 (ja) | 自律走行制御システム、自律走行制御装置、自律走行装置、自律走行制御方法、自律走行制御プログラム | |
| US20210158474A1 (en) | Way to generate images with distortion for fisheye lens | |
| US11318865B2 (en) | Autonomous vehicle having a configurable passenger seat | |
| US20210396532A1 (en) | Mobile-object control device, mobile-object control method, mobile object, information processing apparatus, information processing method, and program | |
| CN113911118A (zh) | 驾驶辅助方法和系统、车辆及计算机可读存储介质 | |
| US20200117209A1 (en) | Small size vehicle | |
| JP2023018962A (ja) | 接触判定システム、接触判定装置、接触判定方法、接触判定プログラム | |
| US20260016831A1 (en) | Control system, control device, control method, storage medium storing control program, autonomous traveling device |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| 121 | Ep: the epo has been informed by wipo that ep was designated in this application |
Ref document number: 22883435 Country of ref document: EP Kind code of ref document: A1 |
|
| WWE | Wipo information: entry into national phase |
Ref document number: 202280069907.6 Country of ref document: CN |
|
| WWE | Wipo information: entry into national phase |
Ref document number: 2022883435 Country of ref document: EP |
|
| NENP | Non-entry into the national phase |
Ref country code: DE |
|
| ENP | Entry into the national phase |
Ref document number: 2022883435 Country of ref document: EP Effective date: 20240521 |
|
| WWG | Wipo information: grant in national office |
Ref document number: 2022883435 Country of ref document: EP |