WO2023209932A1 - 遠隔操作システム - Google Patents
遠隔操作システム Download PDFInfo
- Publication number
- WO2023209932A1 WO2023209932A1 PCT/JP2022/019244 JP2022019244W WO2023209932A1 WO 2023209932 A1 WO2023209932 A1 WO 2023209932A1 JP 2022019244 W JP2022019244 W JP 2022019244W WO 2023209932 A1 WO2023209932 A1 WO 2023209932A1
- Authority
- WO
- WIPO (PCT)
- Prior art keywords
- microphone
- forceps
- sound
- remote control
- control system
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Ceased
Links
Images


Classifications
-
- A—HUMAN NECESSITIES
- A61—MEDICAL OR VETERINARY SCIENCE; HYGIENE
- A61B—DIAGNOSIS; SURGERY; IDENTIFICATION
- A61B17/00—Surgical instruments, devices or methods
- A61B17/28—Surgical forceps
- A61B17/29—Forceps for use in minimally invasive surgery
-
- A—HUMAN NECESSITIES
- A61—MEDICAL OR VETERINARY SCIENCE; HYGIENE
- A61B—DIAGNOSIS; SURGERY; IDENTIFICATION
- A61B34/00—Computer-aided surgery; Manipulators or robots specially adapted for use in surgery
- A61B34/30—Surgical robots
- A61B34/35—Surgical robots for telesurgery
-
- A—HUMAN NECESSITIES
- A61—MEDICAL OR VETERINARY SCIENCE; HYGIENE
- A61B—DIAGNOSIS; SURGERY; IDENTIFICATION
- A61B34/00—Computer-aided surgery; Manipulators or robots specially adapted for use in surgery
- A61B34/30—Surgical robots
- A61B34/37—Leader-follower robots
-
- A—HUMAN NECESSITIES
- A61—MEDICAL OR VETERINARY SCIENCE; HYGIENE
- A61B—DIAGNOSIS; SURGERY; IDENTIFICATION
- A61B34/00—Computer-aided surgery; Manipulators or robots specially adapted for use in surgery
- A61B34/70—Manipulators specially adapted for use in surgery
- A61B34/76—Manipulators having means for providing feel, e.g. force or tactile feedback
-
- A—HUMAN NECESSITIES
- A61—MEDICAL OR VETERINARY SCIENCE; HYGIENE
- A61B—DIAGNOSIS; SURGERY; IDENTIFICATION
- A61B34/00—Computer-aided surgery; Manipulators or robots specially adapted for use in surgery
- A61B34/20—Surgical navigation systems; Devices for tracking or guiding surgical instruments, e.g. for frameless stereotaxis
- A61B2034/2046—Tracking techniques
- A61B2034/2063—Acoustic tracking systems, e.g. using ultrasound
-
- A—HUMAN NECESSITIES
- A61—MEDICAL OR VETERINARY SCIENCE; HYGIENE
- A61B—DIAGNOSIS; SURGERY; IDENTIFICATION
- A61B34/00—Computer-aided surgery; Manipulators or robots specially adapted for use in surgery
- A61B34/30—Surgical robots
- A61B2034/302—Surgical robots specifically adapted for manipulations within body cavities, e.g. within abdominal or thoracic cavities
-
- A—HUMAN NECESSITIES
- A61—MEDICAL OR VETERINARY SCIENCE; HYGIENE
- A61B—DIAGNOSIS; SURGERY; IDENTIFICATION
- A61B34/00—Computer-aided surgery; Manipulators or robots specially adapted for use in surgery
- A61B34/70—Manipulators specially adapted for use in surgery
- A61B34/74—Manipulators with manual electric input means
Definitions
- the actuator may be a voice coil motor capable of vibrating in a range of at least 200 to 400 Hz. This allows the operator to perceive the hardness of the object according to the frequency of the vibration.
- remote refers not only to cases in which the distance between the operator and the object to be operated is physically remote, but also to cases in which the master device operated by the operator and the slave device to be operated are mechanically separated. Also included. In this case, even if the master machine and slave machine are located close to each other, they are still operated remotely.
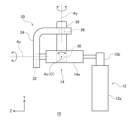
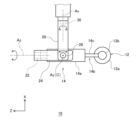
- the movement information of the operating device 10 can be used to control the position and attitude of the manipulator of the slave machine via the gimbal section 20 and the translation mechanism.
- a surgical support robot capable of operating forceps is a slave machine
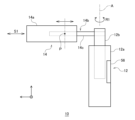
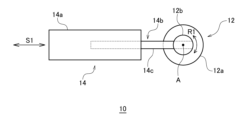
- the operator moves or rotates the entire operating device 10 in a desired direction while grasping the grip portion 12.
- Movement of the operating device 10 is detected by a sensor (not shown) that acquires information (movement information) on the rotation angles of the Z-axis section 22, Y-axis section 26, and X-axis section 30. Movement information detected by the sensor is transmitted to the surgical support robot.
- the surgical support robot controls the position of the forceps based on the transmitted movement information.
Landscapes
- Health & Medical Sciences (AREA)
- Surgery (AREA)
- Engineering & Computer Science (AREA)
- Life Sciences & Earth Sciences (AREA)
- Medical Informatics (AREA)
- Robotics (AREA)
- Biomedical Technology (AREA)
- Heart & Thoracic Surgery (AREA)
- Nuclear Medicine, Radiotherapy & Molecular Imaging (AREA)
- Molecular Biology (AREA)
- Animal Behavior & Ethology (AREA)
- General Health & Medical Sciences (AREA)
- Public Health (AREA)
- Veterinary Medicine (AREA)
- Ophthalmology & Optometry (AREA)
- Manipulator (AREA)
- Selective Calling Equipment (AREA)
Abstract
Description
(1)衝突(感)、対象表面の状態を操作者に知覚させることができる。
(2)力覚の大きさがほぼ0の(誤差に埋もれる)ような接触やその変化でも操作者に知覚させることができる。
(3)触覚伝達機構だけでなく力覚伝達機構と組み合わせることで、操作対象の質感や硬さに対する操作者の知覚の精度を増すことができる。
(4)操作や視覚を邪魔せずシステムのイベント情報(アラームや操作誘導)を触覚として提示できる。
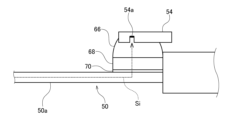
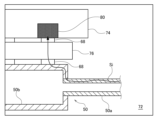
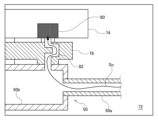
上述の実施の形態では、シャフトに他の部材を介してマイクを取り付けた場合について説明したが、以下の変形例では、鉗子を着脱可能なスレーブ機の本体側にマイクを設けた構成について説明する。
Claims (7)
- 対象へ作用する機器を遠隔で操作する操作装置と、
前記対象と前記機器との接触時の音を検出するマイクロフォンと、
前記操作装置に設けられた、操作者に触覚を提示する触覚提示部と、
前記触覚提示部が提示する触覚に対応する動作を算出する演算部と、を備え、
前記演算部は、前記音に基づいて前記動作を算出することを特徴とする遠隔操作システム。 - 前記触覚提示部は、前記マイクロフォンが検出した音に基づいて駆動するアクチュエータを有することを特徴とする請求項1に記載の遠隔操作システム。
- 前記アクチュエータは、少なくとも200~400Hzの範囲で振動可能なボイスコイルモータであることを特徴とする請求項2に記載の遠隔操作システム。
- 前記機器として手術に用いられる術具を更に備え、
前記マイクロフォンは、前記対象と前記術具とが接触する位置の近傍に設けられていることを特徴とする請求項1乃至3のいずれか1項に記載の遠隔操作システム。 - 前記マイクロフォンは、少なくとも50Hz~1000Hzの範囲の音を集音できることを特徴とする請求項4に記載の遠隔操作システム。
- 前記術具は、シャフトを有する鉗子であり、
前記マイクロフォンは、前記鉗子を着脱可能に保持する本体に設けられており、前記鉗子を伝わった音を検出すること特徴とする請求項4に記載の遠隔操作システム。 - 不潔領域にある前記本体と清潔領域にある前記鉗子とを分離するセパレータを更に備え、
前記セパレータと前記鉗子との間に空気よりも音を伝搬しやすい伝搬部材が挟まれていることを特徴とする請求項6に記載の遠隔操作システム。
Priority Applications (5)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| EP22940208.6A EP4505966A4 (en) | 2022-04-28 | 2022-04-28 | REMOTE CONTROL SYSTEM |
| CN202280094196.8A CN118946328A (zh) | 2022-04-28 | 2022-04-28 | 远程操作系统 |
| JP2023571756A JP7451004B1 (ja) | 2022-04-28 | 2022-04-28 | 遠隔操作システム |
| PCT/JP2022/019244 WO2023209932A1 (ja) | 2022-04-28 | 2022-04-28 | 遠隔操作システム |
| US18/925,189 US20250041013A1 (en) | 2022-04-28 | 2024-10-24 | Remote operation system |
Applications Claiming Priority (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| PCT/JP2022/019244 WO2023209932A1 (ja) | 2022-04-28 | 2022-04-28 | 遠隔操作システム |
Related Child Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| US18/925,189 Continuation US20250041013A1 (en) | 2022-04-28 | 2024-10-24 | Remote operation system |
Publications (1)
| Publication Number | Publication Date |
|---|---|
| WO2023209932A1 true WO2023209932A1 (ja) | 2023-11-02 |
Family
ID=88518166
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| PCT/JP2022/019244 Ceased WO2023209932A1 (ja) | 2022-04-28 | 2022-04-28 | 遠隔操作システム |
Country Status (5)
| Country | Link |
|---|---|
| US (1) | US20250041013A1 (ja) |
| EP (1) | EP4505966A4 (ja) |
| JP (1) | JP7451004B1 (ja) |
| CN (1) | CN118946328A (ja) |
| WO (1) | WO2023209932A1 (ja) |
Citations (6)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| WO2008108289A1 (ja) | 2007-03-01 | 2008-09-12 | Tokyo Institute Of Technology | 力覚提示機能を有する操縦システム |
| JP2016214715A (ja) * | 2015-05-25 | 2016-12-22 | ソニー株式会社 | 振動検出モジュール、振動検出方法及び手術システム |
| WO2018159070A1 (ja) * | 2017-03-03 | 2018-09-07 | リバーフィールド株式会社 | 動力伝達アダプタおよび医療用マニピュレータシステム |
| JP2019130602A (ja) * | 2018-01-30 | 2019-08-08 | ソニー株式会社 | 情報処理装置、情報処理方法、及びプログラム |
| JP2021192130A (ja) * | 2018-08-29 | 2021-12-16 | ソニーグループ株式会社 | 触覚提示装置及び触覚提示システム |
| JP2022048173A (ja) | 2016-10-04 | 2022-03-25 | インテュイティブ サージカル オペレーションズ, インコーポレイテッド | コンピュータ支援遠隔操作手術システムおよび方法 |
Family Cites Families (1)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| US12186043B2 (en) * | 2020-05-29 | 2025-01-07 | Canon U.S.A., Inc. | Robotic endoscope controller with detachable monitor |
-
2022
- 2022-04-28 EP EP22940208.6A patent/EP4505966A4/en active Pending
- 2022-04-28 CN CN202280094196.8A patent/CN118946328A/zh active Pending
- 2022-04-28 JP JP2023571756A patent/JP7451004B1/ja active Active
- 2022-04-28 WO PCT/JP2022/019244 patent/WO2023209932A1/ja not_active Ceased
-
2024
- 2024-10-24 US US18/925,189 patent/US20250041013A1/en active Pending
Patent Citations (6)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| WO2008108289A1 (ja) | 2007-03-01 | 2008-09-12 | Tokyo Institute Of Technology | 力覚提示機能を有する操縦システム |
| JP2016214715A (ja) * | 2015-05-25 | 2016-12-22 | ソニー株式会社 | 振動検出モジュール、振動検出方法及び手術システム |
| JP2022048173A (ja) | 2016-10-04 | 2022-03-25 | インテュイティブ サージカル オペレーションズ, インコーポレイテッド | コンピュータ支援遠隔操作手術システムおよび方法 |
| WO2018159070A1 (ja) * | 2017-03-03 | 2018-09-07 | リバーフィールド株式会社 | 動力伝達アダプタおよび医療用マニピュレータシステム |
| JP2019130602A (ja) * | 2018-01-30 | 2019-08-08 | ソニー株式会社 | 情報処理装置、情報処理方法、及びプログラム |
| JP2021192130A (ja) * | 2018-08-29 | 2021-12-16 | ソニーグループ株式会社 | 触覚提示装置及び触覚提示システム |
Non-Patent Citations (1)
| Title |
|---|
| See also references of EP4505966A4 |
Also Published As
| Publication number | Publication date |
|---|---|
| CN118946328A (zh) | 2024-11-12 |
| EP4505966A4 (en) | 2025-06-11 |
| EP4505966A1 (en) | 2025-02-12 |
| JP7451004B1 (ja) | 2024-03-18 |
| US20250041013A1 (en) | 2025-02-06 |
| JPWO2023209932A1 (ja) | 2023-11-02 |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| JP5152993B2 (ja) | モジュール式力センサ | |
| EP3554412B1 (en) | Actuated grips for controller | |
| EP3691555B1 (en) | End effector force feedback to master controller | |
| Hagn et al. | DLR MiroSurge: a versatile system for research in endoscopic telesurgery | |
| US9333039B2 (en) | Systems and methods for providing vibration feedback in robotic systems | |
| US12370004B2 (en) | Detection of user touch on controller handle | |
| JP6582549B2 (ja) | 振動検出モジュール、振動検出装置、振動検出方法及び手術システム | |
| JP6996510B2 (ja) | 力覚提示装置 | |
| EP3709924A1 (en) | Master control device and methods therefor | |
| CN107708594A (zh) | 用于机器人手术系统的控制臂组合件 | |
| JP2016083581A (ja) | 手術器具のための力およびトルクセンサー | |
| CN113194870B (zh) | 使用者界面装置、手术机器人装置的主控制台及其操作方法 | |
| US8924009B2 (en) | Haptic device for telerobotic surgery | |
| JP2021175500A (ja) | 手術支援ロボット | |
| JP2023010761A (ja) | カメラ制御装置 | |
| WO2018230385A1 (ja) | 情報入力装置並びに医療システム | |
| JP2007143704A (ja) | 超音波探触子移動保持装置 | |
| JP7451004B1 (ja) | 遠隔操作システム | |
| WO2024226481A1 (en) | System and method for controlled ultrasonic sealing and cutting | |
| JP7345010B2 (ja) | 手術支援ロボット | |
| GB2625105A (en) | Control system for a surgical robotic system |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| WWE | Wipo information: entry into national phase |
Ref document number: 2023571756 Country of ref document: JP |
|
| 121 | Ep: the epo has been informed by wipo that ep was designated in this application |
Ref document number: 22940208 Country of ref document: EP Kind code of ref document: A1 |
|
| WWE | Wipo information: entry into national phase |
Ref document number: 202280094196.8 Country of ref document: CN |
|
| WWE | Wipo information: entry into national phase |
Ref document number: 2022940208 Country of ref document: EP |
|
| ENP | Entry into the national phase |
Ref document number: 2022940208 Country of ref document: EP Effective date: 20241108 |
|
| NENP | Non-entry into the national phase |
Ref country code: DE |