Disclosure of Invention
An object of the embodiments of the present application is to provide an identification method for an image identification system, so as to solve the problems in the related art that a fixed camera forms a certain angle with a book, which results in a low content identification rate and a high click-to-read error rate.
In order to achieve the above purpose, the embodiment of the present application adopts the following technical solutions:
an identification method of an image identification system is provided, which adopts the image identification system, and the image identification system comprises:
the camera is used for acquiring image information of a measured object;
the mechanical arm assembly is connected with the camera and used for driving the camera to move;
the main machine body is used for driving the mechanical arm component to move the camera to be right above the specified content of the object to be measured and identify the specified content;
the camera and the manipulator arm assembly are respectively and electrically connected with the main machine body;
the identification method of the image identification system comprises the following steps:
adjusting: the main machine body controls the mechanical arm assembly, the camera is moved to the position above a measured object, and the camera acquires an integral image of the measured object;
specifying: determining specified content on the object to be measured;
identification: the host body controls the mechanical arm assembly to move the camera to the position right above the specified content, and the host body acquires and identifies the specified content through the camera.
In one embodiment, the distance between the camera and the object to be measured in the adjusting step is greater than the distance between the camera and the object to be measured in the identifying step.
In one embodiment, the distance between the camera and the object to be measured in the adjusting step is greater than the distance between the camera and the object to be measured in the identifying step.
In one embodiment, the robot arm assembly comprises a support member and a drive member for driving the support member to move; the camera is installed on the support component, the driving component is connected with the support component, and the host body is electrically connected with the driving component.
In one embodiment, the stand member includes a rotating stand and a telescopic stand mounted on the rotating stand, the camera being mounted on the telescopic stand; the driving component comprises a power part and a transmission part, the power part is used for driving the rotating support to rotate, the transmission part is used for driving the telescopic support to slide on the rotating support, the rotating support is connected with the power part, the transmission part is installed on the rotating support, the transmission part is connected with the telescopic support, and the power part and the transmission part are respectively and electrically connected with the main body.
In one embodiment, the telescopic bracket comprises an arm mounted on the rotary bracket and a connecting arm connected with the arm, the arm is connected with the transmission member, and the camera is mounted on the connecting arm; the driving component also comprises a first power output part for driving the connecting arm to rotate around the supporting arm; the first power output piece is arranged on the support arm and connected with the connecting arm, and the main machine body is electrically connected with the first power output piece.
In one embodiment, the connecting arm comprises a first supporting arm connected with the supporting arm and a second supporting arm connected with the first supporting arm, and the camera is mounted on the second supporting arm; the driving member further comprises a second power output part for driving the second supporting arm to wind the first supporting arm, the first power output part is connected with the first supporting arm, the second power output part is installed on the first supporting arm, the second power output part is connected with the second supporting arm, and the host body is electrically connected with the second power output part.
In one embodiment, the first support arm comprises a plurality of sequentially connected rotating arms, the rotating arm at one end of the first support arm is connected with the support arm, and the rotating arm at the other end of the first support arm is connected with the second support arm; the driving component further comprises third power output pieces used for driving the rotating arms to rotate, each third power output piece is installed on the first supporting arm and connected with the corresponding rotating arm, and the main body is electrically connected with each third power output piece.
In one embodiment, the driving member further comprises a fourth power output element for driving the second support arm to rotate, the fourth power output element is mounted on the first support arm, the fourth power output element is connected with the second support arm, and the main body is electrically connected with the fourth power output element.
In one embodiment, the host body includes:
a main control module;
the cloud identification module is used for uploading the specified content of the measured object acquired by the camera to a database and identifying and acquiring content information; and the number of the first and second groups,
the display module is used for playing and displaying the content information acquired by the cloud identification module;
the cloud identification module and the display module are respectively electrically connected with the main control module.
One or more technical solutions in the embodiments of the present application have at least one of the following technical effects:
the identification method of the image identification system provided by the embodiment of the application has the beneficial effects that: compared with the prior art, the camera is arranged on the mechanical arm component, and the camera can acquire the image information of the measured object. When the fingertip of a user points at the designated content of a measured object, the camera picks up the content indicated by the fingertip and transmits a signal to the host body, the host body drives the mechanical arm assembly to move the camera to the position right above the content indicated by the fingertip at the moment, an image of the content indicated by the fingertip can be clearly obtained through the automatic focusing function of the camera, the content recognition rate is high, the click-to-read error rate is low, and the problems that the content recognition rate is low due to the fact that the fixed camera and a book form a certain angle, and the click-to-read error rate is high due to the fact that the finger is suspended in the air can be effectively solved.
Detailed Description
In order to make the technical problems, technical solutions and advantageous effects to be solved by the present application clearer, the present application is further described in detail below with reference to the accompanying drawings and embodiments. It should be understood that the specific embodiments described herein are merely illustrative of the present application and are not intended to limit the present application.
It will be understood that when an element is referred to as being "secured to" or "disposed on" another element, it can be directly on the other element or be indirectly on the other element. When an element is referred to as being "connected to" another element, it can be directly connected to the other element or be indirectly connected to the other element.
Furthermore, the terms "first", "second", "third", "fourth" are used for descriptive purposes only and are not to be construed as indicating or implying relative importance or implicitly indicating the number of technical features indicated. Thus, a feature defined as "first" or "second" may explicitly or implicitly include one or more of that feature. In the description of the present application, "a plurality" means two or more unless specifically limited otherwise. The meaning of "a number" is one or more unless specifically limited otherwise.
In the description of the present application, it is to be understood that the terms "center", "length", "width", "thickness", "upper", "lower", "front", "rear", "left", "right", "vertical", "horizontal", "top", "bottom", "inner", "outer", and the like, indicate orientations or positional relationships based on those shown in the drawings, and are used only for convenience in describing the present application and for simplicity in description, and do not indicate or imply that the referenced devices or elements must have a particular orientation, be constructed and operated in a particular orientation, and thus, are not to be construed as limiting the present application.
In the description of the present application, it is to be noted that, unless otherwise explicitly specified or limited, the terms "mounted," "connected," and "connected" are to be construed broadly, e.g., as meaning either a fixed connection, a removable connection, or an integral connection; can be mechanically or electrically connected; either directly or indirectly through intervening media, either internally or in any other relationship. The specific meaning of the above terms in the present application can be understood by those of ordinary skill in the art as appropriate.
Reference throughout this specification to "one embodiment" or "an embodiment" means that a particular feature, structure, or characteristic described in connection with the embodiment is included in at least one embodiment of the present application. Thus, the appearances of the phrases "in one embodiment" or "in some embodiments" in various places throughout this specification are not necessarily all referring to the same embodiment. Furthermore, the particular features, structures, or characteristics may be combined in any suitable manner in one or more embodiments.
For convenience of description, three coordinate axes which are mutually vertical in space are defined as an X axis, a Y axis and a Z axis respectively, and meanwhile, the direction along the X axis is longitudinal, the direction along the Y axis is transverse, and the direction along the Z axis is vertical; the X axis and the Y axis are two coordinate axes which are vertical to each other on the same horizontal plane, and the Z axis is a coordinate axis in the vertical direction; the X axis, the Y axis and the Z axis are positioned in space and are mutually vertical, and three planes are respectively an XY plane, a YZ plane and an XZ plane, wherein the XY plane is a horizontal plane, the XZ plane and the YZ plane are vertical planes, and the XZ plane is vertical to the YZ plane. Three axes in space are an X axis, a Y axis and a Z axis, and the three-axis movement in space refers to the movement along three axes which are vertical to each other in space, in particular to the movement along the X axis, the Y axis and the Z axis in space; the planar motion is a motion in the XY plane.
Referring to fig. 1 to 3, an image recognition system provided by the present application will now be described. The image recognition system includes a camera 4 for acquiring image information of an object to be measured 5, a manipulator arm assembly (not shown) supporting the camera 4, and a host body 3. The camera 4 and the mechanical arm component are respectively electrically connected with the host body 3, image information acquired by the camera 4 can be transmitted to the host body 3, the host body 3 can determine the position of the designated content of the measured object 5 through an algorithm and send an instruction to the mechanical arm component, the camera 4 is moved to the position right above the designated content through the mechanical arm component, so that the designated content can be shot by the camera 4, the shot designated content is transmitted to the host body 3 by the camera 4, and then the pointed reading or display and the like are performed after the camera 4 is identified by the host body 3. The camera 4 may be a zoom high-definition camera, so that automatic focusing shooting is realized, and the obtained image information is clear, which is not limited uniquely here.
In the present application, the object to be measured 5 may be a book, a human face, or the like; the designated content can be information such as characters, numbers, images and the like; the image recognition system can be applied to the technical field of point-reading equipment, video calls and the like, and is not limited uniquely.
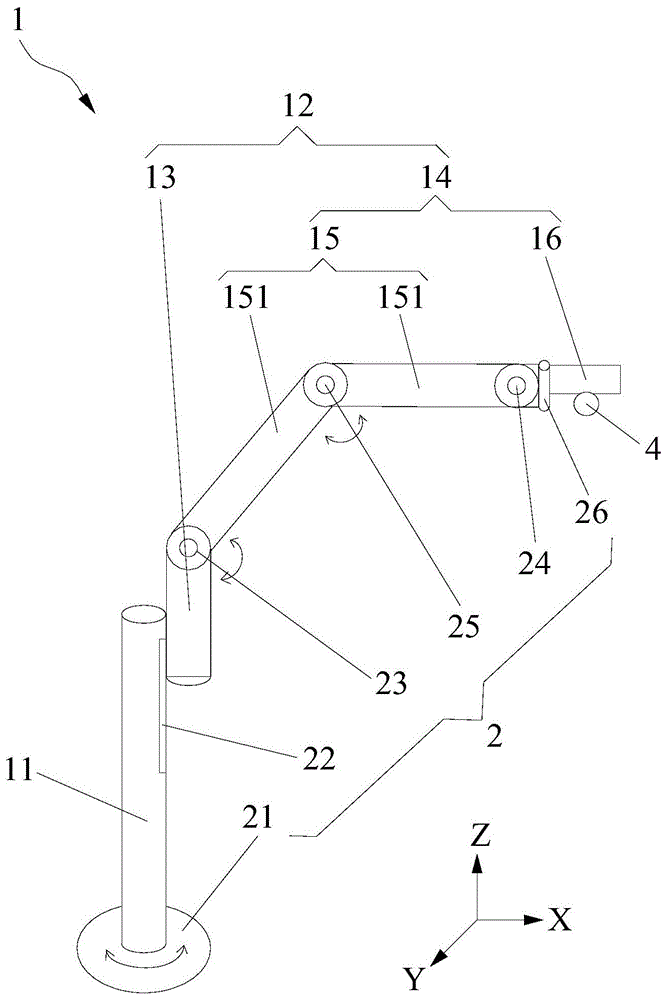
In one embodiment, referring to fig. 1, as one embodiment of the image recognition system provided by the present application, a robot arm assembly includes a support member 1 and a driving member 2 for driving the support member 1 to move; the camera 4 is mounted on the holder member 1, the driving member 2 is connected to the holder member 1, and the main body 3 is electrically connected to the driving member 2. This structure, drive member 2 can realize the control to the length of manipulator arm assembly, height and width, and under manipulator arm assembly's drive, camera 4 can realize the arbitrary removal in XYZ space to improve the variety that camera 4 position removed, and then the adaptation is located the testee 5 of different positions departments.
In one embodiment, referring to fig. 1, as a specific implementation of the image recognition system provided by the present application, the bracket member 1 includes a rotating bracket 11 and a telescopic bracket 12 mounted on the rotating bracket 11, and the camera 4 is mounted on the telescopic bracket 12; the driving member 2 comprises a power piece 21 for driving the rotating bracket 11 to rotate and a transmission piece 22 for driving the telescopic bracket 12 to slide on the rotating bracket 11, the rotating bracket 11 is connected with the power piece 21, the transmission piece 22 is installed on the rotating bracket 11, the transmission piece 22 is connected with the telescopic bracket 12, and the power piece 21 and the transmission piece 22 are respectively and electrically connected with the main body 3. With this configuration, the power unit 21 can drive the rotating bracket 11 to rotate in the horizontal plane with the Z-axis as the rotation axis, and thus the camera 4 can be driven to rotate in the horizontal plane by the telescopic bracket 12. The driving medium 22 can drive the telescopic bracket 12 to move up and down along the rotating bracket 11, so that the height of the camera 4 can be adjusted, the distance between the camera 4 and the measured object 5 can be conveniently shortened, the image acquired by the camera 4 is clear, and the identification accuracy is improved. The power member 21 and the transmission member 22 may be a stepping motor, a servo motor, etc., and are not limited herein.
In one embodiment, referring to fig. 1, as an embodiment of the image recognition system provided by the present application, the telescopic bracket 12 includes a support arm 13 mounted on the rotating bracket 11 and a connecting arm 14 connected to the support arm 13, the support arm 13 is connected to the transmission member 22, and the camera 4 is mounted on the connecting arm 14; the drive member 2 further comprises a first power take-off 23 for driving the connecting arm 14 in rotation about the arm 13; the first power output member 23 is mounted on the arm 13, the first power output member 23 is connected with the connecting arm 14, and the main body 3 is electrically connected with the first power output member 23. With the structure, the first power output part 23 can drive the connecting arm 14 to rotate around the supporting arm 13 in a vertical plane, so as to adjust the distance between the camera 4 and the object to be measured 5. The connecting arm 14 can rotate 360 degrees around the supporting arm 13, and the position of the camera 4 can be flexibly adjusted. The first power output member 23 may be a stepping motor, a servo motor, etc., and is not limited herein.
In one embodiment, referring to fig. 1, as an embodiment of the image recognition system provided by the present application, the connecting arm 14 includes a first supporting arm 15 connected to the supporting arm 13 and a second supporting arm 16 connected to the first supporting arm 15, and the camera 4 is mounted on the second supporting arm 16; the driving member 2 further comprises a second power output part 24 for driving the second support arm 16 to rotate around the first support arm 15, the first power output part 23 is connected with the first support arm 15, the second power output part 24 is mounted on the first support arm 15, the second power output part 24 is connected with the second support arm 16, and the main body 3 is electrically connected with the second power output part 24. With the structure, the first power output part 23 can drive the first support arm 15 to rotate 360 degrees in the vertical plane around the support arm 13, and the second power output part 24 can drive the second support arm 16 to rotate 360 degrees in the vertical plane around the first support arm 15, so that the photographing position of the camera 4 can be adjusted in a diversified manner. The camera 4 can be positioned at a certain coordinate of the cylindrical space whose radius is the length of the connecting arm 14 and whose height is the sum of the lengths of the rotating bracket 11 and the first support arm 15, and the positional adjustment of the camera 4 is diversified. The second power output member 24 may be a stepping motor, a servo motor, etc., and is not limited herein.
In an embodiment, referring to fig. 1, as a specific implementation of the image recognition system provided by the present application, the first support arm 15 includes a plurality of sequentially connected rotating arms 151, the rotating arm 151 located at one end of the first support arm 15 is connected to the support arm 13, and the rotating arm 151 located at the other end of the first support arm 15 is connected to the second support arm 16; the drive member 2 further comprises a third power take-off 25 for driving each of the rotary arms 151 in rotation; each third power output member 25 is mounted on the first support arm 15, each third power output member 25 is connected to the corresponding rotating arm 151, and the main body 3 is electrically connected to each third power output member 25. In this structure, the rotating arm 151 at one end is connected to the first power output member 23, and is driven by the first power output member 23 to rotate 360 degrees in a vertical plane around the support arm 23. Each third power output member 25 can drive the corresponding rotating arm 151 to rotate 360 degrees around the adjacent rotating arm 151 in the vertical plane, so that the first supporting arm 15 can be extended and retracted, and the position diversity of the camera 4 is improved. The third power output element 25 may be a stepping motor, a servo motor, etc., and is not limited herein.
In one embodiment, referring to fig. 1, the first support arm 15 includes two rotation arms 151, the two rotation arms 151 are connected end to end, the first power output member 23 drives one rotation arm 151 to rotate 360 degrees in a vertical plane around the support arm 13, a third power output member 25 is mounted on the rotation arm 151, the third power output member 25 is connected to the other rotation arm 151, and can drive the other rotation arm 151 to rotate 360 degrees in the vertical plane around the first rotation arm 151. The second power take-off 24 is mounted on a further swivel arm 151 and carries the second support arm 16 about this swivel arm 151 for 360-degree rotation in the vertical plane. In other embodiments, the number, the rotation manner, and the like of the rotation arms 151 included in the first support arm 15 can be adjusted according to actual needs, and are not limited herein.
In an embodiment, referring to fig. 1, as a specific implementation of the image recognition system provided by the present application, the driving member 2 further includes a fourth power output element 26 for driving the second support arm 16 to rotate, the fourth power output element 26 is mounted on the first support arm 15, the fourth power output element 26 is connected to the second support arm 16, and the host body 3 is electrically connected to the fourth power output element 26. With the structure, the fourth power output part 26 can drive the second support arm 16 to rotate 360 degrees in the horizontal plane around the first support arm 15, so that the position change diversity of the camera 4 is improved. The fourth power output member 26 may be a stepping motor, a servo motor, etc., and is not limited herein.
In an embodiment, referring to fig. 3, as a specific implementation manner of the image recognition system provided in the present application, the host body 3 includes a main control module 31, a cloud recognition module 32 for uploading the designated content of the object to be detected 5 acquired by the camera 4 to a database and recognizing the acquired content information, and a display module 33 for playing and displaying the content information acquired by the cloud recognition module 32; the cloud identification module 32 and the display module 33 are electrically connected to the main control module 31. With the structure, after the camera 4 acquires the specified content of the object to be measured 5, the specified content is approved and compared with the content stored in the database, so as to identify the target content of the specified content, and finally, the identified target content is subjected to voice playing or video display and the like through the display module 33. The database may be an online database or a local database, and the like, and is not limited herein.
Referring to fig. 4, the present application further provides an identification method, which adopts the image identification system, and includes the following specific steps:
adjusting S1: the main machine body 3 controls the mechanical arm component to move the camera 4 to the upper side of the measured object 5, and the camera 4 obtains the whole image of the measured object 5. This structure, after placing measured object 5 with the support table face on, start image recognition system, manipulator arm assembly moves camera 4 to the top position of measured object 5 under the drive of host computer body 3 this moment to make camera 4 can acquire the whole image of measured object 5.
Designation of S2: the specified contents are determined on the object to be measured 5. This structure is explained by taking a finger of a user as an example. The content of the finger tip of the user on the measured object 5 is the designated content. In other embodiments, the designated content may also be determined by a touch-and-talk pen, a circle, or the like, which is not limited herein.
Recognizing S3: the main body 3 controls the mechanical arm assembly to move the camera 4 to a position right above the specified content, and the main body 3 acquires and identifies the specified content through the camera 4. Can set up horizontal detection module in the host computer body 3, but through this horizontal detection module real-time supervision camera 4 whether be in the horizontal plane to can ensure to remove camera 4 to appointed content directly over.
Please refer to fig. 2, which illustrates an example of a fingertip. Before the identification, the host body 3 continuously identifies whether a finger exists in the whole image acquired by the camera 4 through a fingertip algorithm. After the finger tip designates Q on the measured object 5 as the designated content, the camera 4 acquires the whole image in which the finger exists, at this time, the host body 3 drives the mechanical arm assembly to move the camera 4 to the position right above the Q, the camera 4 acquires the complete and clear image of the Q, and transmits the image information to the host body 3 and compares the image information with the database so as to identify and determine the specific content information of the Q, and can perform voice playing or video display and the like through the display module 33.
In the step of identifying S3, the distance between the camera 4 and the object to be measured 5 is smaller than the distance between the camera 4 and the object to be measured 5 in the step of adjusting S1. With the adoption of the structure, the distance between the camera 4 and the designated content Q is shortened, so that the image shot by the camera 4 is clearer, and the identification accuracy of the designated content Q is improved.
According to the image recognition system and the recognition method thereof, the camera 4 can be moved to the position right above the designated content through the mechanical arm component, so that the designated content can be clearly shot, the problem that the image of the fixed-focus wide-angle camera 4 at a near place is distorted is solved, the problem that the spatial resolution is low, and the problem that the image of the measured object 5 shot at a far place is fuzzy and the recognition is poor is solved. Compared with a certain included angle between the camera 4 and the measured object 5, the camera 4 is not positioned right above the designated content, and the content under the tip of the misidentification finger exists, so that misidentification is caused. By moving the camera 4 to the position right above the designated content, the content pointed by the finger cannot be identified by mistake even if the finger tip is suspended, so that the problem of error identification caused by suspension of the finger can be effectively solved, and the point reading error rate is reduced.
The above description is only exemplary of the present application and should not be taken as limiting the present application, as any modification, equivalent replacement, or improvement made within the spirit and principle of the present application should be included in the protection scope of the present application.