CN213975642U - Transfer robot - Google Patents
Transfer robot Download PDFInfo
- Publication number
- CN213975642U CN213975642U CN202022577256.2U CN202022577256U CN213975642U CN 213975642 U CN213975642 U CN 213975642U CN 202022577256 U CN202022577256 U CN 202022577256U CN 213975642 U CN213975642 U CN 213975642U
- Authority
- CN
- China
- Prior art keywords
- platform
- wheel core
- belt
- transfer robot
- power supply
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Active
Links
- 238000012546 transfer Methods 0.000 title claims abstract description 61
- 230000005540 biological transmission Effects 0.000 claims abstract description 115
- 238000004804 winding Methods 0.000 claims abstract description 40
- 230000007246 mechanism Effects 0.000 claims description 38
- 239000004020 conductor Substances 0.000 claims description 17
- 239000002184 metal Substances 0.000 claims description 15
- 229910052751 metal Inorganic materials 0.000 claims description 15
- 239000011810 insulating material Substances 0.000 claims description 6
- 239000012811 non-conductive material Substances 0.000 claims description 3
- 230000009977 dual effect Effects 0.000 abstract description 3
- 230000009286 beneficial effect Effects 0.000 abstract description 2
- 239000000463 material Substances 0.000 description 11
- 238000004891 communication Methods 0.000 description 7
- 229910000831 Steel Inorganic materials 0.000 description 6
- 238000010586 diagram Methods 0.000 description 6
- 238000000034 method Methods 0.000 description 6
- 239000010959 steel Substances 0.000 description 6
- RYGMFSIKBFXOCR-UHFFFAOYSA-N Copper Chemical compound [Cu] RYGMFSIKBFXOCR-UHFFFAOYSA-N 0.000 description 5
- 229910052802 copper Inorganic materials 0.000 description 5
- 239000010949 copper Substances 0.000 description 5
- 230000009471 action Effects 0.000 description 3
- 238000012423 maintenance Methods 0.000 description 3
- 230000008569 process Effects 0.000 description 3
- 230000001681 protective effect Effects 0.000 description 3
- 230000002349 favourable effect Effects 0.000 description 2
- 239000007769 metal material Substances 0.000 description 2
- 238000005096 rolling process Methods 0.000 description 2
- 238000013519 translation Methods 0.000 description 2
- OKTJSMMVPCPJKN-UHFFFAOYSA-N Carbon Chemical compound [C] OKTJSMMVPCPJKN-UHFFFAOYSA-N 0.000 description 1
- 238000004026 adhesive bonding Methods 0.000 description 1
- 230000008901 benefit Effects 0.000 description 1
- 229910052799 carbon Inorganic materials 0.000 description 1
- 230000008859 change Effects 0.000 description 1
- 230000000739 chaotic effect Effects 0.000 description 1
- 230000001143 conditioned effect Effects 0.000 description 1
- 238000001514 detection method Methods 0.000 description 1
- 230000005611 electricity Effects 0.000 description 1
- 238000009413 insulation Methods 0.000 description 1
- 238000002955 isolation Methods 0.000 description 1
- 238000012986 modification Methods 0.000 description 1
- 230000004048 modification Effects 0.000 description 1
- 230000000750 progressive effect Effects 0.000 description 1
- 230000009467 reduction Effects 0.000 description 1
- 230000008054 signal transmission Effects 0.000 description 1
Images



Landscapes
- Manipulator (AREA)
Abstract
The utility model discloses a transfer robot, including power module, first reel device, first drive belt, binding post, second drive belt, the second reel device that concatenates in proper order and constitute power supply loop. Wherein: the two winding wheel devices are arranged on the first platform and driven by the driving device to rotate; one end of the first transmission belt is fixedly connected with the conductive part of the first reel device and electrically connected with the conductive part, and the other end of the first transmission belt is electrically connected with the wiring terminal and fixedly connected with the second platform so as to pull the second platform to translate; one end of the second transmission belt is fixedly connected with the conductive part of the second reel device and electrically connected with the conductive part, and the other end of the second transmission belt is electrically connected with the wiring terminal and fixedly connected with the second platform so as to pull the second platform to move horizontally; the power supply module and the wiring terminal are respectively arranged on the first platform and the second platform. The transmission system of the transfer robot has dual functions of transmission and electric conduction, and is beneficial to simplifying the equipment structure and the circuit arrangement.
Description
Technical Field
The utility model relates to an automatic storage technical field, in particular to transfer robot.
Background
An automated warehouse is a system capable of automatically storing and taking out materials without direct manual intervention, and is generally composed of multiple shelves, wherein the materials are usually stored in standard bins or trays, and then are accessed by a handling manipulator (or called a handling robot), and automatic access control and management of the materials are realized by a computer.
SUMMERY OF THE UTILITY MODEL
An object of the utility model is to provide a transfer robot, its transmission system has electrically conductive function, is favorable to simplifying equipment structure, subtracts change circuit arrangement, reduces equipment occupation space. Further, the transfer robot can avoid the occurrence of disturbance of the current supply between the drive shaft and the transmission mechanism due to a short circuit.
In order to achieve the above object, the utility model provides a following technical scheme:
the utility model provides a transfer robot, includes first platform and second platform to and in proper order series connection constitutes power supply circuit's power module, first reel device, first drive belt, binding post, second drive belt, second reel device, wherein:
the first winding wheel device and the second winding wheel device are arranged on the first platform and driven by a driving device to rotate; one end of the first transmission belt is fixedly connected with the conductive part of the first reel device and electrically connected with the conductive part, and the other end of the first transmission belt is electrically connected with the wiring terminal and fixedly connected with the second platform so as to pull the second platform to translate; one end of the second transmission belt is fixedly connected with the conductive part of the second reel device and electrically connected with the conductive part, and the other end of the second transmission belt is electrically connected with the wiring terminal and fixedly connected with the second platform so as to pull the second platform to translate;
the power supply module is arranged on the first platform, and the wiring terminal is arranged on the second platform; or, the wiring terminal is arranged on the first platform, and the power supply module is arranged on the second platform.
Optionally, in the transfer robot, the power supply module is a battery or a rectifier;
the first transmission belt is a direct current positive electrode input, and the second transmission belt is a direct current negative electrode output.
Alternatively, in the above transfer robot, both the first belt and the second belt may be metal belts.
Optionally, in the above transfer robot, an electrical connector is provided on each of the first reel device and the second reel device, the electrical connector including a fixed portion and a rotating portion, wherein:
the fixing part is provided with a fixing cable used for being connected with electrical equipment, and the electrical equipment is the power supply module arranged on the first platform or the wiring terminal arranged on the first platform;
the rotating part is provided with the rotating cable, and the outer connecting end of the rotating cable is electrically connected with the side end face of the conductive part of the reel device.
Alternatively, in the above transfer robot, the first belt and the second belt are collectively referred to as a belt; the first winding wheel device and the second winding wheel device are collectively called as a winding wheel device, the winding wheel device comprises an inner layer wheel core and an outer layer wheel core, wherein:
the inner layer wheel core is made of an insulating material and is in transmission connection with the driving device;
the outer-layer wheel core is made of conductive materials, is sleeved outside the inner-layer wheel core and is fixedly connected with the inner-layer wheel core;
if the driving device drives the winding wheel device to rotate, the driving belt is wound on the outer layer wheel core to pull the second platform to translate.
Optionally, in the transfer robot described above, the outer layer wheel core includes a wheel core main body portion and a wheel core connecting portion, wherein:
the wheel core main body part is sleeved outside the inner layer wheel core and fixedly connected with the inner layer wheel core;
the wheel core connecting part and the wheel core main body part are spliced to form a roller structure for winding the transmission belt, and a splicing seam between the wheel core connecting part and the wheel core main body part is used for clamping and establishing the connecting end of the transmission belt and is fixedly connected with the connecting end.
Optionally, in the transfer robot, one end of the outer wheel core is provided with a first guide mechanism for axially limiting the driving belt, the first guide mechanism is fixedly connected to a first side end surface of the outer wheel core, and:
the first guide mechanism is made of conductive materials and is provided with an electrical interface used for being connected with the rotating cable of the electric connector, so that the outer-layer wheel core can be electrically connected with the electric connector;
or, the first guiding mechanism is made of a conductive material or a non-conductive material and is provided with a through hole, and the through hole is used for allowing the rotating cable of the electric connector to pass through so as to enable the rotating cable to be electrically connected with the outer layer wheel core.
Alternatively, in the transfer robot described above, the power supply module is provided on the first stage, the connection terminal is provided on the second stage, and the first stage is located above the second stage.
Optionally, in the transfer robot, the first platform is a master station for controlling the second platform to ascend and descend, and the second platform is a slave station for gripping the target object.
Optionally, in the transfer robot, the power supply module is a switching power supply;
the wiring terminal is connected with load equipment arranged on the second platform, and the load equipment comprises a PLC and/or a sensor and/or a direct current motor.
According to the above technical scheme, the utility model provides an among the transfer robot, first reel device, first drive belt, second reel device can be used for adjusting the distance between first platform and the second is two-dimensionally as the transmission system between first platform and the second platform. Moreover, the transmission system also has a conductive function, and can supply power for load equipment connected with the wiring terminal on the second platform through the power supply module on the first platform. That is to say, the transmission system in this transfer robot has transmission and electrically conductive dual function simultaneously to simplified equipment structure, simplified the circuit arrangement, reduced equipment occupation space.
Furthermore, the transmission system in the transfer robot can realize the basic transmission function, and the rolling wheel device adopts a double-layer structure, and the inner layer wheel core is made of insulating materials, so that the insulating isolation is realized between the driving device and the outer layer wheel core, the problem of power connection between the driving device and the outer layer wheel core (or the problem of power connection between the driving device and a transmission belt) can be effectively avoided, and the situations of short circuit and disordered power supply between a driving shaft, a transmission mechanism and other parts in the transfer robot are avoided.
Drawings
In order to more clearly illustrate the embodiments of the present invention or the technical solutions in the prior art, the drawings used in the description of the embodiments or the prior art will be briefly described below, it is obvious that the drawings in the following description are only some embodiments of the present invention, and for those skilled in the art, other drawings can be obtained according to these drawings without creative efforts.
Fig. 1 is a schematic view of a current trend of a power supply loop of a transfer robot according to a second embodiment of the present invention (arrows indicate current trends);
fig. 2 is a schematic view of an overall structure of a transfer robot according to a second embodiment of the present invention;
FIG. 3 is a first isometric view of a first platform provided with a drive belt according to a second embodiment of the present invention;
FIG. 4 is a second isometric view of a first platform provided with a drive belt according to a second embodiment of the present invention;
fig. 5 is a schematic diagram of a connection mode of the transmission mechanism according to the second embodiment of the present invention;
fig. 6 is a schematic diagram illustrating another connection mode of the transmission mechanism according to the second embodiment of the present invention;
fig. 7 is a schematic view of an overall structure of a reel device provided with a protective cover according to a second embodiment of the present invention;
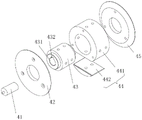
fig. 8 is an exploded schematic view of a reel device according to a second embodiment of the present invention;
fig. 9 is a schematic view of an overall structure of a reel device according to a second embodiment of the present invention;
fig. 10 is a schematic view of an assembly structure of an inner layer wheel core, an outer layer wheel core and a first guiding mechanism according to a second embodiment of the present invention;
fig. 11 is a schematic view of a current flow direction of a power supply circuit of a transfer robot according to a third embodiment of the present invention (arrows indicate current flow directions).
Wherein:
1-a first platform, 2-a second platform, 3-a transmission belt, 4-a winding wheel device,
401-a first reel means, 402-a second reel means,
403-third reel device, 404-fourth reel device,
41-electrical connector, 411-stationary cable, 422-rotating cable,
42-first guide means, 421-electrical interface, 422-screw,
43-inner layer wheel core, 431-driving shaft mounting hole, 432-groove,
44-outer layer wheel core, 441-wheel core main body portion, 442-wheel core connecting portion,
45-second guiding mechanism, 46-protective cover;
5-a power supply module, 6-a wiring terminal,
7-a first control system, 8-a second control system,
10-a drive shaft, the drive shaft,
31-a first belt, 32-a second belt,
33-third belt, 34-fourth belt.
Detailed Description
The technical solutions in the embodiments of the present invention will be described clearly and completely with reference to the accompanying drawings in the embodiments of the present invention, and it is obvious that the described embodiments are only some embodiments of the present invention, not all embodiments. Based on the embodiments in the present invention, all other embodiments obtained by a person skilled in the art without creative work belong to the protection scope of the present invention.
First embodiment
The utility model discloses a first concrete embodiment provides a transfer robot, and this transfer robot includes top platform and below platform. Wherein:
a transmission mechanism for adjusting the distance between the upper platform and the lower platform is arranged between the upper platform and the lower platform, such as a gear transmission mechanism, a drag chain transmission mechanism, a belt transmission mechanism and the like;
communication devices for realizing automatic control, such as wireless communication devices arranged on the upper platform and the lower platform, or signal detection devices, signal transmission devices and signal receiving devices arranged on the upper platform and the lower platform, and communication cables arranged between the upper platform and the lower platform, are also arranged between the upper platform and the lower platform;
the upper platform or the lower platform is provided with a power supply module, and the lower platform and the upper platform are electrically connected through a power transmission cable to realize power supply.
Because the reel among the drive mechanism is mostly the metal material, its drive shaft of connecting also is the metal material, when the drive belt between upper and lower platform adopted the steel band, the copper strips, electrically conductive rubber or other electrically conductive material and connect power module, perhaps the drive belt between upper and lower platform adopted the steel band, the copper strips, electrically conductive rubber or other electrically conductive material and have the communication function when, especially when being provided with multiunit drive mechanism between top platform and the below platform, then take place the drive shaft easily, take place the short circuit between the multicomponent such as drive mechanism, thereby take place the circular telegram confusion, the chaotic condition of communication.
In addition, in the prior art, how to simplify the wiring layout of the equipment and how to reduce the occupied space of the equipment are also technical problems faced by those skilled in the art at present.
Second embodiment
The utility model discloses a second concrete embodiment provides a transfer robot, and its transmission system has electrically conductive function, is favorable to simplifying equipment structure, and the simplification circuit is arranged, reduces equipment occupation space. Further, the transfer robot can avoid short-circuiting and disturbance of current supply between a plurality of components such as a drive shaft and a transmission mechanism.
Referring to fig. 1 to 10, fig. 1 is a schematic diagram illustrating a structure of a supply current trend of a transfer robot according to a second embodiment of the present invention; fig. 2 is a schematic view of an overall structure of a transfer robot according to a second embodiment of the present invention; FIG. 3 is a first isometric view of a first platform provided with a drive belt according to a second embodiment of the present invention; FIG. 4 is a second isometric view of a first platform provided with a drive belt according to a second embodiment of the present invention; fig. 5 is a schematic diagram of a connection mode of the transmission mechanism according to the second embodiment of the present invention; fig. 6 is a schematic diagram illustrating another connection mode of the transmission mechanism according to the second embodiment of the present invention; fig. 7 is a schematic view of an overall structure of a reel device provided with a protective cover according to a second embodiment of the present invention; fig. 8 is an exploded schematic view of a reel device according to a second embodiment of the present invention; fig. 9 is a schematic view of an overall structure of a reel device according to a second embodiment of the present invention; fig. 10 is an assembly structure diagram of an inner layer wheel core, an outer layer wheel core and a first guiding mechanism according to a second embodiment of the present invention.
The utility model discloses transfer robot that second embodiment provided, including first platform 1 and second platform 2 to and establish ties in proper order and constitute power supply circuit's power module 5, first reel device 401, first drive belt 31, binding post 6, second drive belt 32, second reel device 402. Wherein:
in order to form a power supply circuit, the first reel device 401, the second reel device 402, the first transmission belt 31 and the second transmission belt 32 need to be made of conductive materials wholly or partially, and the connection parts can be conductive;
the power supply module 5 is arranged on the first platform 1, and the wiring terminal 6 is arranged on the second platform 2;
the first winding wheel device 401 and the second winding wheel device 402 are arranged on the first platform 1 and are in transmission connection with the driving device so as to be driven to rotate by a driving shaft 10 of the driving device;
one end of the first transmission belt 31 is fixedly connected with the conductive part of the first reel device 401 and electrically connected with the conductive part, and the other end of the first transmission belt 31 is electrically connected with the wiring terminal 6 and fixedly connected with the second platform 2 so as to pull the second platform 2 to translate;
one end of the second transmission belt 32 is fixedly connected and electrically connected with the conductive portion of the second reel device 402, and the other end of the second transmission belt 32 is electrically connected with the connection terminal 6 and fixedly connected with the second platform 2 so as to pull the second platform 2 to move horizontally.
When in work: the driving device connected with the first reel device 401 and the second reel device 402 is fixedly arranged on the first platform 1, and the first reel device 401 and the second reel device 402 rotate synchronously, so that the second platform 2 can be pulled through the first transmission belt 31 and the second transmission belt 32, and the lifting movement of materials (including a material box) or the translation in other directions is realized.
It can be seen from the above technical solution that, in the transfer robot provided by the second embodiment of the present invention, the first reel device 401, the first transmission belt 31, the second transmission belt 32, and the second reel device 402 can be used to adjust the distance between the first platform 1 and the second platform 2 as the transmission system between the first platform 1 and the second platform 2. Moreover, the transmission system has an electric conduction function, and can supply power to load equipment connected with the connecting terminal 6 on the second platform 2 through the power supply module 5 on the first platform 1. That is to say, the transmission system in this transfer robot has transmission and electrically conductive dual function simultaneously to simplified equipment structure, simplified the circuit arrangement, reduced equipment occupation space.
Specifically, the power supply module 5 in the transfer robot is a rectifier, an input of which is alternating current (e.g., AC220V), an output of which is direct current (e.g., DC24V), the first driving belt 31 is a direct current positive input (e.g., 24V +), and the second driving belt 32 is a direct current negative output (e.g., 24V-). But is not limited thereto, and in other embodiments, other types of power supply modules, such as batteries or others, may be used according to actual needs.
Specifically, in the above transfer robot, the first and second belts 31 and 32 are preferably metal belts, such as steel belts or copper belts. However, the present invention is not limited to this, and in other embodiments, the first driving belt 31 and the second driving belt 32 may be made of conductive rubber or other conductive materials, or may be made by combining a common driving belt with a conductive material, such as covering a layer of conductive material on the common driving belt, or nesting a metal cable, or engraving a metal wire. No matter which kind of mode is adopted to make the drive belt have the electrically conductive function, all are based on the utility model discloses the core thought obtains, all is in the utility model discloses within the scope of claiming.
In specific implementation, the transmission mechanism where the first transmission belt 31 and the second transmission belt 32 are located needs to meet the transmission requirement of the transmission system and the conduction requirement of the power supply circuit at the same time. For example, in a transfer robot, the first platform 1 is located above the second platform 2, the transmission system is used between the two platforms, and the transmission belt 3 is a metal belt (for example, 301 steel metal belt), and the parameters of the metal belt are as follows:
tensile strength σ b (mpa): not less than 480
Conditioned yield strength σ 0.2 (MPa): not less than 205
Elongation δ 5 (%): not less than 40
Reduction of area ψ (%): not less than 60
Hardness: 187HB or less; less than or equal to 90 HRB; less than or equal to 200HV
Resistivity ρ: less than or equal to 1 omega mm2·m-1
Thickness: 0.1 to 0.3mm
Width: not less than 10mm
Length: less than or equal to 10m
Specifically, referring to fig. 4 to 10, in the above transfer robot, the first reel device 401 and the second reel device 402 are collectively referred to as a reel device 4, an electrical connector 41 is provided on the reel device 4, and the electrical connector 41 includes a fixed portion and a rotating portion. Wherein: the fixed part of the electrical connector 41 is provided with a fixed cable 411 for connecting with an electrical device, which is the power supply module 5 arranged on the first platform 1; the rotating portion of the electrical connector 41 is provided with a rotating cable 412, and an outer end of the rotating cable 412 is electrically connected to a side end surface of the conductive portion of the reel unit 4 (see fig. 5 and 6 in particular).
Specifically, referring to fig. 5, an electrical interface 421 for connecting with the rotating cable 412 of the electrical connector 41 is disposed on a side end of the reel device 4 (or the first guiding mechanism 42 fixedly connected to the side end of the reel device) so that a conductive portion (for example, an outer core 44 described below) of the reel device 4 can be electrically connected with the electrical connector 41.
Alternatively, referring to fig. 6, a first guiding mechanism 42 is disposed at a side end of the reel device 4, the first guiding mechanism 42 is made of a conductive material (or a non-conductive material), and is provided with a through hole for allowing the rotation cable 412 of the electrical connector 41 to pass through so that the rotation cable 412 can be electrically connected with a conductive portion (e.g., an outer core 44, hereinafter referred to) of the reel device 4. At this time, the external connection end of the rotation cable 412 of the electrical connector 41 is inserted into the through hole, and is in contact with the outer layer core 43 made of conductive material to ensure electrical connection therebetween, and then the rotation cable 412 is fastened in the through hole by a connector such as a screw 422.
In particular, the electrical connector 41 may employ conductive slip rings or carbon brushes or other electrical connectors capable of achieving a rotational electrical connection.
Specifically, referring to fig. 4 to 10, in the transfer robot, the first belt 31 and the second belt 32 are collectively referred to as a belt 3, and the belt 3 is a metal belt. The first reel device 401 and the second reel device 402 are collectively referred to as a reel device 4.
Wherein, the winding wheel device 4 comprises an inner layer wheel core 43 and an outer layer wheel core 44: the inner layer wheel core 43 is made of insulating materials, is in transmission connection with the driving device and is driven to rotate by the driving device; the outer layer wheel core 44 is made of conductive material, is sleeved outside the inner layer wheel core 43 and is fixedly connected with the inner layer wheel core; if the driving device drives the winding wheel device 4 to rotate, the driving belt 3 winds on the outer layer wheel core 44 to pull the second platform 2 to translate.
When in work: the driving device connected with the winding wheel device 4 is fixedly arranged on the first platform 1, when the driving device drives the inner layer wheel core 43 to rotate, the winding wheel device 4 integrally rotates, and the second platform 2 can be pulled through the driving belt 3 matched with the winding wheel device 4, so that the lifting movement of materials (including a material box) or the translation in other directions is realized.
It should be noted that the handling robot may be used for lifting and lowering materials (including bins), and may also be used for translating the handled materials in other directions, for example:
if the first platform 1 is arranged right above the second platform 2, the second platform 2 can be controlled to lift through a winding wheel device and a transmission belt 3;
if the first platform 1 and the second platform 2 are horizontally arranged, the second platform 2 can be pulled to horizontally move through the rolling wheel device and the transmission belt 3 so as to carry materials in the horizontal direction;
if the first platform 1 and the second platform 2 are arranged along an inclined plane, the second platform 2 can be pulled to move in the inclined plane through the reel device and the driving belt 3 so as to realize the transportation of materials in the inclined plane.
According to the technical scheme, the transmission system in the transfer robot can realize a basic transmission function, and the winding wheel device adopts a double-layer structure, the inner layer wheel core 43 is made of an insulating material, so that the driving device and the outer layer wheel core 44 are insulated and isolated, the problem of the power connection between the driving device and the outer layer wheel core 44 (or the problem of the power connection between the driving device and the transmission belt 3) can be effectively avoided, and the situations of short circuit and power supply disorder between a driving shaft, a transmission mechanism and other parts in the transfer robot are avoided.
Specifically, referring to fig. 8 to 10, the outer layer wheel core 44 includes a wheel core main body portion 441 and a wheel core connecting portion 442, wherein: the wheel core main body part 441 is sleeved outside the inner layer wheel core 43 and fixedly connected with the inner layer wheel core; the wheel core connecting portion 442 and the wheel core main body portion 441 are spliced to form a roller structure for winding the transmission belt 3, and a splicing seam between the wheel core connecting portion 442 and the wheel core main body portion 441 is used for clamping and setting a connecting end of the transmission belt 3 and is fixedly connected with the connecting end.
Specifically, the splice between the core attaching portion 442 and the core main body portion 441 is a planar-type seam a parallel to the center axis of the outer-layer core 44.
Specifically, the wheel core connecting portion 442 and the wheel core main body portion 441, and the outer layer wheel core 44 and the inner layer wheel core 43 are fixedly connected by radial screws, respectively.
Specifically, a drive shaft mounting hole 431 adapted to the drive shaft of the drive device and a groove 432 for extending the cable are provided in the inner-layer wheel core 43.
Specifically, a first guide mechanism 42 and a second guide mechanism 45 are respectively arranged at two ends of the outer-layer wheel core 44, and the first guide mechanism 42 and the second guide mechanism 45 can play a role in axial limiting and guiding for the driving belt 3. Preferably, the first guide mechanism 42 and the second guide mechanism 45 are respectively in the form of an annular limiting plate, and the two guide mechanisms are respectively and fixedly connected with the end face of the outer-layer wheel core 44 through axial screws.
But is not so limited and in other embodiments:
the splicing seam between the wheel core connecting part 442 and the wheel core main body part 441 can also be arranged in other structural forms, such as a step shape, an arc shape and the like;
the connection between the inner core 43 and the drive shaft may be made by other means, such as a spline connection;
other connecting pieces or other connecting structures can be respectively adopted to be fixedly connected between the outer-layer wheel core 44 and the inner-layer wheel core 43, between the wheel core connecting portion 442 and the wheel core main body portion 441 of the outer-layer wheel core 44, and between the annular limiting plate and the outer-layer wheel core 44, for example, the fixedly connection can be realized by adopting one or more combined modes of multiple connecting modes such as conductive adhesive bonding, clamping, threaded connection, connecting piece fixing and the like.
Specifically, referring to fig. 10, in the winding wheel device 4, the first guiding mechanism 42 is fixedly connected to a first side end surface of the outer layer wheel core 44; the second guiding mechanism 45 is an annular limiting member fixedly connected to the second side end surface of the outer wheel core 44, and a central through hole thereof is used for allowing the driving shaft of the driving device to extend into the driving shaft mounting hole 431 of the inner wheel core 43.
Further, referring to fig. 4 and 7, in an implementation, a protective cover 46 may be disposed outside the outer layer core 44 to prevent the transmission belt 3 from being accidentally flicked and damaged or other components from being damaged, and also to prevent the transmission belt 3 or the outer layer core 44 from contacting other components to cause short circuit.
For convenience of understanding, the following description will be made in detail by taking a transfer robot as an example of a transfer robot for lifting: in the transfer robot, the power supply module 5 is provided on the first stage 1, the connection terminal 6 is provided on the second stage 2, and the first stage 1 is located above the second stage 2. When the lifting device works, the winding wheel device rotates, and the first platform 1 controls the second platform 2 to lift through the winding wheel device 4 and the transmission belt 3. At this time, the power supply module 5 is disposed on the first platform 1 above, mainly for safety reasons, so as to avoid a safety hazard when the AC220V passes through the metal belt, for example, a safety hazard occurs when the transmission belt 3 made of a conductive material is broken and grounded.
Specifically, in the above transfer robot, the first platform 1 is a master station for controlling the second platform 2 to ascend and descend, and the second platform 2 is a slave station for gripping the target object. Further, the master station can also control the equipment to walk. Furthermore, the power supply module 5 is a switching power supply, the input of which is AC220V, and the output of which is DC 24V; the connection terminals 6 are connected to load devices provided on the second platform 2, which load devices comprise controllers (e.g. PLCs, i.e. "programmable logic controllers") and/or sensors and/or direct current motors.
Specifically, in the transfer robot, two, four or more sets of transmission systems (one transmission belt and one winding wheel device form one set of transmission system) are arranged between the first platform 1 and the second platform 2, wherein at least two sets of transmission systems are used as conductive media to form the power supply circuit, and the rest of transmission systems can be specifically arranged according to actual needs. For example, referring to fig. 2 to 4, in the above-mentioned transfer robot, not only the first reel device 401, the second reel device 402, the first transmission belt 31 and the second transmission belt 32 for forming a power supply circuit (for convenience of expression, it is referred to as a power supply circuit D) are provided for supplying power to the connection terminal 6 on the second platform 2 through the power supply module 5 on the first platform 1; further, a third reel device 403, a fourth reel device 404, a third belt 33, and a fourth belt 34 are provided. Wherein:
the structures and the arrangements of the third reel device 403, the fourth reel device 404, the third transmission belt 33 and the fourth transmission belt 34 are respectively the same as those of the first reel device 401, the second reel device 402, the first transmission belt 31 and the second transmission belt 32, and can be used as standby devices of the first reel device 401, the second reel device 402, the first transmission belt 31 and the second transmission belt 32, when the first reel device 401, the second reel device 402, the first transmission belt 31 and the second transmission belt 32 are damaged and need to be maintained, the standby devices are replaced to continuously meet the power supply requirement;
or, the structures and arrangements of the third reel device 403, the fourth reel device 404, the third transmission belt 33 and the fourth transmission belt 34 are respectively the same as those of the first reel device 401, the second reel device 402, the first transmission belt 31 and the second transmission belt 32, and respectively form a standby loop with another power supply module and another connection terminal, when the power supply loop D is damaged and needs maintenance, the power supply loop D is replaced by the power supply loop D to continue power supply;
the third reel device 403, the fourth reel device 404, the third belt 33, and the fourth belt 34 may be configured and arranged in the same manner as the first reel device 401, the second reel device 402, the first belt 31, and the second belt 32, respectively, and may form a communication circuit with the first controller on the first platform 1 and the second controller on the second platform as communication media.
To sum up, the utility model discloses drive belt 3 among the transfer robot that third embodiment provided not only is used for the transmission, still is used for electrically conducting between first platform 1 and second platform 2, the during operation:
a first winding wheel device 401 and a second winding wheel device 402 are arranged on the first platform 1, the first winding wheel device 401 is connected with the second platform 2 through a first transmission belt 31, and the second winding wheel device 402 is connected with the second platform 2 through a second transmission belt 32; an inner layer wheel core in the first winding wheel device 401 and an inner layer wheel core in the second winding wheel device 402 are both connected with the driving shaft 10 so as to be driven to rotate through the driving shaft 10, and the inner layer wheel core in the first winding wheel device 401 and the inner layer wheel core in the second winding wheel device 402 are both made of insulating materials, so that insulation can be realized between the first winding wheel device 401 and the second winding wheel device 402;
the power supply module 5 is arranged on the first platform 1, the wiring terminal 6 is arranged on the second platform 2, at least one group of transmission systems (one group of transmission systems comprises a reel device and a metal belt) is arranged between the first platform 1 and the second platform 2, and therefore the power supply module 5, the first reel device 401, the first transmission belt 31, the wiring terminal 6, the second transmission belt 32 and the second reel device 402 form a power supply loop (or a conductive loop), and power is supplied to load equipment which is positioned on the second platform 2 and connected with the wiring terminal 6 through the power supply module 5 positioned on the first platform 1.
The first belt 31 and the second belt 32 are used to supply 24V dc to the second platform 2, wherein the first belt 31 is 24V dc and the second belt 32 is 24V dc.
It is therefore clear that the utility model provides an among the transfer robot that the second embodiment provided, adopt the strap as the drive belt to can make strap and the outer core wheel 44 of winding wheel device as conductive medium, satisfy simultaneously in the automation warehouse transfer robot (be transfer robot) transmission requirement and the electrically conductive requirement between the upper and lower platform. Moreover, the two reel devices which coaxially rotate are insulated from the driving shaft in transmission connection with the reel devices, so that short circuit is avoided.
It should be noted that when a metal belt is used as the transmission belt 3, it is preferable to use an exposed steel belt, a copper belt or other conductive material. When metal strips are used for DC24V supply, there is no electric shock hazard due to the lower than safe voltage.
To sum up, the utility model discloses the transfer robot that the second embodiment provided has following advantage:
(1) compared with the scheme that a battery and a common cable are adopted for conducting electricity between an upper platform and a lower platform and a common transmission mechanism is adopted for transmission, the carrying robot provided by the second specific embodiment of the utility model uses a metal belt (steel belt, copper belt or other conductive media) as a transmission belt and has a conductive function at the same time, thereby realizing the purpose of multiple purposes of one object and saving the common cable, so that the structure is more compact, the occupied space is less, the cost is saved, and the maintenance is avoided;
(2) the metal belt has small flexibility, high strength and small friction relative to the belt or other transmission media, thereby being beneficial to prolonging the service life of equipment and reducing the maintenance cost.
Third embodiment
Referring to fig. 11, a third embodiment of the present invention provides a transfer robot, which is different from the transfer robot provided by the second embodiment only in that: the power supply module 5 is arranged on the second platform 2, the connection terminal 6 is arranged on the first platform 1, so that the fixed cable 411 in the electric connector 41 on the winding wheel device 4 is connected with the connection terminal 6, and two ends of the transmission belt 3 are respectively and electrically connected with the electric connector 41 and the power supply module 5.
Finally, it should also be noted that, herein, relational terms such as first and second, and the like may be used solely to distinguish one entity or action from another entity or action without necessarily requiring or implying any actual such relationship or order between such entities or actions. Also, the terms "comprises," "comprising," or any other variation thereof, are intended to cover a non-exclusive inclusion, such that a process, method, article, or apparatus that comprises a list of elements does not include only those elements but may include other elements not expressly listed or inherent to such process, method, article, or apparatus. Without further limitation, an element defined by the phrase "comprising an … …" does not exclude the presence of other identical elements in a process, method, article, or apparatus that comprises the element.
The embodiments in the present description are described in a progressive manner, each embodiment focuses on differences from other embodiments, and the same and similar parts among the embodiments are referred to each other.
The previous description of the disclosed embodiments is provided to enable any person skilled in the art to make or use the present invention. Various modifications to these embodiments will be readily apparent to those skilled in the art, and the generic principles defined herein may be applied to other embodiments without departing from the spirit or scope of the invention. Thus, the present invention is not intended to be limited to the embodiments shown herein but is to be accorded the widest scope consistent with the principles and novel features disclosed herein.
Claims (10)
1. The utility model provides a transfer robot, its characterized in that includes first platform (1) and second platform (2) to and in proper order series connection and constitute power module (5), first reel device (401), first drive belt (31), binding post (6), second drive belt (32), second reel device (402) of power supply circuit, wherein:
the first reel device (401) and the second reel device (402) are arranged on the first platform (1) and driven to rotate by a driving device; one end of the first transmission belt (31) is fixedly connected with the conductive part of the first reel device (401) and forms an electric connection, and the other end of the first transmission belt (31) is electrically connected with the wiring terminal (6) and is fixedly connected with the second platform (2) so as to pull the second platform (2) to translate; one end of the second transmission belt (32) is fixedly connected with the conductive part of the second winding wheel device (402) and forms an electric connection, and the other end of the second transmission belt (32) is electrically connected with the wiring terminal (6) and is fixedly connected with the second platform (2) so as to pull the second platform (2) to translate;
the power supply module (5) is arranged on the first platform (1), and the wiring terminal (6) is arranged on the second platform (2); or, the wiring terminal (6) is arranged on the first platform (1), and the power supply module (5) is arranged on the second platform (2).
2. A handling robot as claimed in claim 1, characterised in that said power supply module (5) is a battery or a rectifier;
the first transmission belt (31) is a direct current positive electrode input, and the second transmission belt (32) is a direct current negative electrode output.
3. The transfer robot as claimed in claim 1, wherein the first and second belts (31, 32) are both metal belts.
4. The transfer robot according to claim 1, wherein the first reel device (401) and the second reel device (402) are each provided with an electrical connector (41), the electrical connectors (41) including a stationary portion and a rotating portion, wherein:
the fixing part is provided with a fixing cable (411) used for being connected with electrical equipment, and the electrical equipment is the power supply module (5) arranged on the first platform (1) or the wiring terminal (6) arranged on the first platform (1);
the rotating part is provided with a rotating cable (412), and the external connection end of the rotating cable (412) is electrically connected with the side end face of the conducting part of the winding wheel device (4).
5. The transfer robot as claimed in claim 4, wherein the first belt (31) and the second belt (32) are collectively referred to as a belt (3); said first reel means (401) and said second reel means (402) being collectively referred to as reel means (4), said reel means (4) comprising an inner layer core (43) and an outer layer core (44), wherein:
the inner layer wheel core (43) is made of insulating materials and is in transmission connection with the driving device;
the outer layer wheel core (44) is made of conductive materials, is sleeved outside the inner layer wheel core (43) and is fixedly connected with the inner layer wheel core;
if the driving device drives the winding wheel device (4) to rotate, the driving belt (3) winds on the outer layer wheel core (44) so as to pull the second platform (2) to translate.
6. The transfer robot of claim 5, wherein the outer layer wheel core (44) includes a wheel core main body portion (441) and a wheel core attachment portion (442), wherein:
the wheel core main body part (441) is sleeved outside the inner layer wheel core (43) and fixedly connected with the inner layer wheel core;
the wheel core connecting portion (442) and the wheel core main body portion (441) are spliced to form a roller structure used for winding the transmission belt (3), and a splicing seam between the wheel core connecting portion (442) and the wheel core main body portion (441) is used for clamping and setting a connecting end of the transmission belt (3) and is fixedly connected with the connecting end.
7. A handling robot as claimed in claim 5, characterized in that one end of the outer wheel core (44) is provided with a first guiding means (42) for axially limiting the drive belt (3), the first guiding means (42) being secured to a first side end face of the outer wheel core (44), and:
the first guide mechanism (42) is made of conductive material and is provided with an electrical interface (421) for connecting with the rotating cable (412) of the electric connector (41) so as to enable the outer layer wheel core (44) to be electrically connected with the electric connector (41);
or, the first guide mechanism (42) is made of conductive or non-conductive material and is provided with a through hole for allowing the rotating cable (412) of the electric connector (41) to pass through so as to enable the rotating cable (412) to be electrically connected with the outer layer wheel core (44).
8. A transfer robot according to any one of claims 1-7, characterized in that the power supply module (5) is provided on the first platform (1), the connection terminal (6) is provided on the second platform (2), and the first platform (1) is located above the second platform (2).
9. A transfer robot as claimed in claim 8, characterized in that the first platform (1) is a master station for controlling the lifting of the second platform (2), and the second platform (2) is a slave station for gripping a target part.
10. A transfer robot as claimed in claim 9, wherein said power supply module (5) is a switching power supply;
the wiring terminal (6) is connected with load equipment arranged on the second platform (2), and the load equipment comprises a PLC and/or a sensor and/or a direct current motor.
Priority Applications (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| CN202022577256.2U CN213975642U (en) | 2020-11-09 | 2020-11-09 | Transfer robot |
Applications Claiming Priority (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| CN202022577256.2U CN213975642U (en) | 2020-11-09 | 2020-11-09 | Transfer robot |
Publications (1)
| Publication Number | Publication Date |
|---|---|
| CN213975642U true CN213975642U (en) | 2021-08-17 |
Family
ID=77262127
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| CN202022577256.2U Active CN213975642U (en) | 2020-11-09 | 2020-11-09 | Transfer robot |
Country Status (1)
| Country | Link |
|---|---|
| CN (1) | CN213975642U (en) |
Cited By (1)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN112499077A (en) * | 2020-11-09 | 2021-03-16 | 深圳市鲸仓科技有限公司 | Transfer robot |
-
2020
- 2020-11-09 CN CN202022577256.2U patent/CN213975642U/en active Active
Cited By (2)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN112499077A (en) * | 2020-11-09 | 2021-03-16 | 深圳市鲸仓科技有限公司 | Transfer robot |
| CN112499077B (en) * | 2020-11-09 | 2024-07-30 | 深圳市鲸仓科技有限公司 | A transport robot |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| JP7565407B2 (en) | Opportunistic charging system for automated storage and retrieval systems | |
| EP4097028B1 (en) | Apparatus and method for charging a load handling device | |
| JP2691117B2 (en) | Rechargeable battery charger for electric vehicles | |
| US6476572B2 (en) | Power supply system and method for dock equipment | |
| CA2907791C (en) | Conveying platform | |
| US20190140525A1 (en) | Conductor arrangement and transportable electrical drive device | |
| US20180086558A1 (en) | Automatic storage facility vehicles and method of providing power | |
| CN213975641U (en) | Transfer robot | |
| CN211687379U (en) | Magnetic suspension production transfer chain and electricity core equipment production system | |
| CN213568043U (en) | Reel device and transmission system | |
| CN112499077A (en) | Transfer robot | |
| CN112374049A (en) | Reel device and transmission system | |
| CN112224734A (en) | Transfer robot | |
| CN110993206A (en) | Insulating layer cladding device for wire and cable | |
| JP7754113B2 (en) | Power supply equipment | |
| JP2006174548A (en) | Collector wheel for cordless power transmission | |
| CN101682554B (en) | A communication interface between a control unit and a high voltage unit | |
| JP4457386B2 (en) | Current collecting wheel for cordless power transmission | |
| KR20230142961A (en) | A device for supplying the electric power to hoistcar | |
| CN208746066U (en) | A kind of vehicle charging carrying power supply unit | |
| JP3303764B2 (en) | Non-contact power supply | |
| KR102719993B1 (en) | Power supply apparatus and systems for OHCV | |
| CN215248731U (en) | Large-tonnage ultrahigh pressure pre-stress wire winding machine | |
| CN218560957U (en) | Lifting equipment | |
| CN223526448U (en) | Debugging system and production line |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| GR01 | Patent grant | ||
| GR01 | Patent grant |