EP0139054B1 - Verfahren zum Steuern des Aus- und Einfahrens von mehrstufigen Teleskopauslegern - Google Patents
Verfahren zum Steuern des Aus- und Einfahrens von mehrstufigen Teleskopauslegern Download PDFInfo
- Publication number
- EP0139054B1 EP0139054B1 EP83306403A EP83306403A EP0139054B1 EP 0139054 B1 EP0139054 B1 EP 0139054B1 EP 83306403 A EP83306403 A EP 83306403A EP 83306403 A EP83306403 A EP 83306403A EP 0139054 B1 EP0139054 B1 EP 0139054B1
- Authority
- EP
- European Patent Office
- Prior art keywords
- boom
- length
- cylinder
- detected
- fore
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Expired
Links
- 238000000034 method Methods 0.000 title claims description 16
- 230000008602 contraction Effects 0.000 claims description 28
- 239000012530 fluid Substances 0.000 claims description 20
- 230000007935 neutral effect Effects 0.000 claims description 5
- 238000010586 diagram Methods 0.000 description 2
- 230000000717 retained effect Effects 0.000 description 2
- 238000004804 winding Methods 0.000 description 2
- 230000000903 blocking effect Effects 0.000 description 1
- 238000010276 construction Methods 0.000 description 1
- 238000007796 conventional method Methods 0.000 description 1
- 238000001514 detection method Methods 0.000 description 1
Images


Classifications
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B66—HOISTING; LIFTING; HAULING
- B66C—CRANES; LOAD-ENGAGING ELEMENTS OR DEVICES FOR CRANES, CAPSTANS, WINCHES, OR TACKLES
- B66C23/00—Cranes comprising essentially a beam, boom, or triangular structure acting as a cantilever and mounted for translatory of swinging movements in vertical or horizontal planes or a combination of such movements, e.g. jib-cranes, derricks, tower cranes
- B66C23/62—Constructional features or details
- B66C23/64—Jibs
- B66C23/70—Jibs constructed of sections adapted to be assembled to form jibs or various lengths
- B66C23/701—Jibs constructed of sections adapted to be assembled to form jibs or various lengths telescopic
- B66C23/705—Jibs constructed of sections adapted to be assembled to form jibs or various lengths telescopic telescoped by hydraulic jacks
Definitions
- This invention relates to a method for controlling the telescopic extension and contraction of a multistage boom of a crane or the like in an efficient manner.
- Multistage booms generally used on cranes or the like are of the telescopic type, (see for example Japanese patent specifications, 56-75388 and 56-78795) which has its modulus of section reduced gradually toward the fore ends of the telescopic boom portions and which is designed to extend firstly a boom portion with the largest modulus of section having the greatest boom strength and to contract firstly a boom portion with the smallest modulus of section during the contracting operation. Therefore, in controlling the extension and contraction of a three stage boom, for example, the ideal procedure is to extend and contract the telescopic boom portions successively, extending the fore boom portion after the intermediate boom portion is fully extended during extension, and contracting the intermediate boom portion after complete contraction of the fore boom portion during contraction.
- the former method is costly since it necessitates to provide a take-up reel for winding the electrical cables which connect the limit switches to the electromagnetic valve in relation with the telescopic operation of the boom, in addition to the above-mentioned two limit switches for detecting the fully extended state of the intermediate boom portion and the fully contracted state of the distal boom portion, respectively.
- the latter method has a problem that it likewise requires provision of costly boom operating cylinders and a complicated hydraulic control circuit.
- the present invention provides a method for controlling the boom operating cylinders during expansion and contraction of a multistage telescopic boom including a base boom portion, an intermediate boom portion and a fore boom portion, said method being characterised by: detecting the length of said boom by means of a boom length detector;
- the present invention also provides apparatus for controlling the boom operating cylinders during expansion and contraction of a multistage telescopic boom including a base boom portion, an intermediate boom portion and a fore boom portion, said apparatus being characterised by:
- FIG. 1 there is shown an example of a multistage (three-stage) boom including a fore boom portion 3 which is telescopically fitted in an intermediate boom portion 2 which is in turn telescopically fitted in a base boom portion 1.
- a first cylinder 4 for operating the intermediate boom portion 2 is provided between the base and intermediate boom portions 1 and 2
- a second cylinder (5) for operating the fore boom portion 3 is provided between the base and intermediate and fore boom portions 2 and 3.
- the first and second cylinders 4 and 5 are sequentially actuated to (a) extend the boom, by switching from the first cylinder 4 to the second cylinder 5 exactly at the point when the intermediate boom portion 2 is fully extended relative to the base boom portion 1 and (b) contract the boom, by switching from the second cylinder 5 to the first cylinder 4 exactly at the point when the fore boom portion 3 is fully contracted relative to the intermediate boom portion 2 as shown by solid line in Figure 1.
- the actual boom length L at this time point is constant.
- the boom length detector 6 may comprise a potentiometer which is mounted, via gears, on the axis of a wire winding drum of a springloaded wire retractor 6a which thereby measures the length of wire 6b pulled out from the drum when the boom is extended, the front end of the wire 6b being securely fixed to a base end portion of the fore boom member 3.
- the boom length detector 6 detects the extended boom length with a good degree of accuracy in most cases, but the detected value inevitably contains an error of about plus or minus 10 cm. If the error is expressed by (a), the detected boom length (1) of the boom which has actually a length L when in the position indicated in solid line in Figure 1, is
- an arbitrary length (b) (eg of 20-50 cm) which is greater than the error (a) is preselected to determine a first reference value (L-b) which is the actual length of the boom in the position of Figure 1 minus the preselected value (b), and a second reference value (L+b) which is the actual length L of the boom plus the preselected value (b).
- the first cylinder 4 alone is actuated to extend or contract only the intermediate boom portion 2 of the detected boom length (1) of the detector 6 is smaller than (L-b) and the second cylinder 5 alone is actuated to extend or contract the fore boom portion 3 if the output value (1) of the detector 6 is greater than (L+b).
- the boom length or the detected boom length (1) of the boom length detector 6 changes due to the telescopic motion of the boom at a velocity (v) which is expressed by
- one cylinder which has been in operation comes to the end of its stroke and the telescopic velocity of the boom becomes zero.
- the cylinders 4 and 5 should be switched when the telescopic velocity becomes zero.
- the variation per unit time (V) of the detected boom length (1) which represents the telescopic velocity (v) of the boom, need only be detected when the detected boom length (1) of the boom length detector 6 is in the range S between the first reference value (L-b) and the second reference value (L+b).
- boom extending fluid chambers 4a and 5a of the first and second cylinders 4 and 5 are separately connected to conduits 9 and 10 through counterbalance valves 7 and 8, respectively, and the conduits 9 and 10 are selectively connected to a main conduit 12 by a pilot change-over valve 11.
- the boom contracting oil chambers 4b and 5b of the first and second cylinders 4 and 5 communicate with each other through an intermediate conduit 13 and are connected to a main circuit 14 in parallel relation with each other.
- the main circuits 12 and 14 are selectively connectable either to a hydraulic pump P serving as a pressure source or to a tank T by the operation of a boom extension/contraction control valve 15 which switches the flow direction of the pressure medium thereby to extend or contract the cylinders 4 and 5.
- a boom extension/contraction control valve 15 which switches the flow direction of the pressure medium thereby to extend or contract the cylinders 4 and 5.
- Indicated at 16 is an operating lever of the control valve 15.
- the pilot change over valve 11 is connected to an accumulator 18 through an electromagnetic valve 17 which is actuated by an electric change-over signal from an electric control circuit operated according to the logic circuit shown in Figure 4 thereby to supply the pilot pressure from the accumulator 18 to the pilot change over valve 11.
- the change-over valve 11 is switched to select either the extension or contraction of the cylinder 4 or 5.
- the control circuit includes a microprocessor 20 as shown in Figure 4 and the logic circuit of Figure 3 is provided in the form of a programme in the microprocessor 20.
- a microprocessor which is already provided on the crane for the control of the overload detector system.
- Such a microprocessor is already supplied with the detected boom length (1) from the boom length detector 6 sequentially at predetermined time intervals, and it can easily perform the operations of comparing the detected boom length (1) with the respective reference values and detecting the variation per unit time of the detected boom length (1), for the on-off control of the relay R, by incorporating a programme corresponding to the logic circuit of Figure 3.
- the switch Rs is turned on and off according to the on-off control of the relay R to energise and de-energise the solenoiod 17', accurately switching the position of the electromagnetic valve 17 of Figure 12.
- the boom extension/contraction control valve 15 of Figure 2 is switched to the right position 15A by manipulating the lever 16, whereupon the output fluid pressure of the hydraulic pump P is fed in the direction of arrow A1 and admitted into the pilot change-over valve 11.
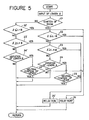
- the detected boom length (1) from the boom length detector 6 is fed to the control circuit, more particularly, to a discriminator 21 (see Figure 3) of the control circuit to make a judgement as to whether the boom is to be extended or contracted. In this instance, the boom is to be extended, so that the detected boom length (1) is fed to a discriminator 22 through YES circuit of the discriminator 21 for comparison with the first reference value (L-b).
- the detected boom length (1) becomes greater than the first reference value (L-b), so that the detected boom length (1) is fed to the discriminator 23 for comparison with the second reference value (L+b).
- the detected boom length (1) is still smaller than the second reference value (L+b) at this time and the detected boom length (1) is fed to the discriminator 24 through the NO circuit of the discriminator 23 to determine if the variation (V) of the detected boom length (1) per unit time is greater than a predetermined value.
- the control treats the discriminator 23 as if it were not included in the control sequence.
- the signal is fed to a relay-on circuit 26' through the YES circuit of the discriminator 24, turning on the relay R of Figure 4 and energising the solenoid 17' through the switch Rs to shift the electromagnetic valve 17 to the right position in Figure 2. Consequently, the fluid pressure from the accumulator 18 is led in the direction of arrow A4 to shift the pilot change-over valve 11 into the upper position in the same figure, stopping the supply of fluid pressure to the first cylinder 4 and instead feeding the fluid pressure in the direction A5 from the main circuit 12 for admission into the extending fluid chamber 5a of the second cylinder 5.
- the fluid pressure in the contracting chamber 5b of the second cylinder 5 is drained in the direction of arrow A6 for return to the tank T.
- the first cylinder 4 is stopped with the intermediate boom portion 2 held in a fully extended position relative to the base boom portion 1, while the fore boom portion 3 alone is extended out of the intermediate boom portion 2 by the extension of the second cylinder 5.
- the detected boom length (1) becomes greater than the second reference value (L+b) by further extension of the boom, the detected boom length (1) is fed to the relay-on circuit 26' through the YES circuit of the discriminator 23, holding the electromagnetic valve 17 in the right position in the figure to permit the extension of the fore boom portion 3 by the second cylinder 5 alone.
- the intermediate boom portion 2 is firstly extended out of the base boom portion 1 by the first cylinder 4, and the electromagnetic valve 17 shifted when the first cylinder 4 comes to it stroke end, that is to say, when the intermediate boom portion 2 is fully extended, thereby stretching the second cylinder 2 to extend the fore boom portion 3 out of the intermediate boom portion 2.
- the boom extension/contraction control valve 15 is shifted to the left position 15B in the figure to supply the output fluid pressure of the hydraulic pump P in the direction of arrow B1 into the contracting fluid chamber 4b of the first cylinder 4 to contract same.
- the detector 6 is fed to the discriminator 22' through the NO circuit of the discriminator 21 as shown in Figure 3.
- the detected boom length is large and its detected boom length (1) is greater than the first reference value (L-b) and the second reference value (L+b) in the initial stage of the boom contracting operation, so that the detected boom length (1) is fed to the relay-on circuit 26' through the NO and YES circuits of the discriminators 22' and 23', respectively, to turn on the relay R.
- the solenoid 17' is energised to shift the electromagnetic valve 17 into the right hand position in Figure 2, and the fluid pressure from the accumulator 18 is fed in the direction of arrow B2 to shift the pilot change-over valve 11 into the upper position, blocking the conduit 9 and instead connecting the conduit 10 to the main circuit 12.
- the fluid pressure flowing in the direction of arrow B1 is fed in the direction of arrow B3 and admitted into the contracting fluid pressure in the extending chamber 5a of the second cylinder 5 is drained in the direction of arrow B4 and returned to the tank T. Consequently, the first cylinder 4 remains stationary without expanding or contracting holding the intermediate boom portion 2 in the fully extended state relative to the base boom portion 1, so that only the fore boom portion retracts into the intermediate boom portion by the contraction of the second cylinder 5.
- the detected boom length (1) is fed to the discriminator 24' through the NO circuit of the discriminator 23' to check if the variation per unit time (V) of the detected boom length (1) is greater than a predetermined value. If the variation (V) is greater than the predetermined value (implying that the second cylinder 5 has not yet reached the end of its stroke), the signal is returned to the initial point of control through the NO circuit of the discriminator 24'. Therefore, the electromagnetic valve 17 is retained in the current position, so that the fore boom portion 3 is still retracted by the second cylinder 5.
- the detected value (1) is fed to the relay-off circuit 26 through the YES circuit of the discriminator 22' to hold the electromagnetic valve 17 in the initial position shown, so that the intermediate boom portion 2 is retracted into the base boom portion 1 by the first cylinder 4 along with the fore boom portion 3.
- the detected boom length (1) of the boom length detector 6 is smaller than the first reference value (L-b) atthe time of re-starting the telescopic motion
- the detected signal (1) is fed to the relay off circuit 26 through the YES circuit of the discriminator 22 or 22' to hold the electromagnetic valve 17 and pilot change over valve 11 in the positions shown. Therefore, the second cylinder 5 remains in a de-activated state and only the first cylinder is actuated to extend or retract the intermediate boom portion 2 relative to the base boom portion 1.
- the detected boom length (1) is greater than the second reference value (L+b)
- the detected signal is fed to the relay-on circuit 26' through the YES circuit of the discriminator 23 or 23' to shift the electromagnetic valve 17 into the right-hand position and the pilot change-over valve 11 into the upper position in the Figure. Accordingly, thefirst cylinder remains still, and only the second cylinder is actuated to extend or retract the fore boom portion 3 relative to the intermediate boom portion 2.
- the control upon re-starting the telescopic operation of the boom, the control would recommence from the point at which the electromagnetic valve 17 was switched, the cylinder of the next stage extending or contracting with the cylinder of the prior stage left in a position short of the end of its stroke.
Landscapes
- Engineering & Computer Science (AREA)
- Mechanical Engineering (AREA)
- Jib Cranes (AREA)
- Forklifts And Lifting Vehicles (AREA)
Claims (6)
Priority Applications (2)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| EP83306403A EP0139054B1 (de) | 1983-10-21 | 1983-10-21 | Verfahren zum Steuern des Aus- und Einfahrens von mehrstufigen Teleskopauslegern |
| DE8383306403T DE3371900D1 (en) | 1983-10-21 | 1983-10-21 | Method for controlling stretching and contracting operations of telescopic multistage boom |
Applications Claiming Priority (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| EP83306403A EP0139054B1 (de) | 1983-10-21 | 1983-10-21 | Verfahren zum Steuern des Aus- und Einfahrens von mehrstufigen Teleskopauslegern |
Publications (2)
| Publication Number | Publication Date |
|---|---|
| EP0139054A1 EP0139054A1 (de) | 1985-05-02 |
| EP0139054B1 true EP0139054B1 (de) | 1987-06-03 |
Family
ID=8191323
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| EP83306403A Expired EP0139054B1 (de) | 1983-10-21 | 1983-10-21 | Verfahren zum Steuern des Aus- und Einfahrens von mehrstufigen Teleskopauslegern |
Country Status (2)
| Country | Link |
|---|---|
| EP (1) | EP0139054B1 (de) |
| DE (1) | DE3371900D1 (de) |
Families Citing this family (1)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN115477239B (zh) * | 2022-07-04 | 2023-04-04 | 韶关市起重机厂有限责任公司 | 一种电控实现的起重机顺序伸缩系统 |
Citations (2)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JPS5675388A (en) * | 1979-11-16 | 1981-06-22 | Unic Corp | Expansion device for boom |
| JPS5678795A (en) * | 1980-10-06 | 1981-06-27 | Unic Corp | Successive working cylinder device for multistage expansion boom |
Family Cites Families (7)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| US2761285A (en) * | 1953-09-03 | 1956-09-04 | Julian B Beecroft | Control system for power-operated moving members |
| US3672257A (en) * | 1969-03-17 | 1972-06-27 | Tadano Tekkosho Kk | Extension means of a multi-stage boom |
| JPS5028593B1 (de) * | 1970-01-14 | 1975-09-17 | ||
| US3809248A (en) * | 1970-02-13 | 1974-05-07 | Tadano Tekkosho Kk | Boom extension means |
| DD100691A1 (de) * | 1972-12-14 | 1973-10-05 | ||
| US4125974A (en) * | 1977-07-08 | 1978-11-21 | Harnischfeger Corporation | Control system for telescopic boom |
| US4286386A (en) * | 1977-09-06 | 1981-09-01 | Long Irvin E | Electro-mechanical displacement measuring device |
-
1983
- 1983-10-21 DE DE8383306403T patent/DE3371900D1/de not_active Expired
- 1983-10-21 EP EP83306403A patent/EP0139054B1/de not_active Expired
Patent Citations (2)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JPS5675388A (en) * | 1979-11-16 | 1981-06-22 | Unic Corp | Expansion device for boom |
| JPS5678795A (en) * | 1980-10-06 | 1981-06-27 | Unic Corp | Successive working cylinder device for multistage expansion boom |
Also Published As
| Publication number | Publication date |
|---|---|
| DE3371900D1 (en) | 1987-07-09 |
| EP0139054A1 (de) | 1985-05-02 |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| US4589076A (en) | Method for controlling stretching and contracting operations of telescopic multistage boom | |
| US5184699A (en) | Control device for forklift | |
| KR100479373B1 (ko) | 변속 시스템의 솔레노이드 제어 엑츄에이터용 고장 검출 시스템 및 방법 | |
| GB2287011A (en) | Stabilising telescopic booms | |
| EP0331177B1 (de) | Vorrichtung zur Beherrschung der Arbeitsreaktion einer Winde | |
| US4125974A (en) | Control system for telescopic boom | |
| KR930000373Y1 (ko) | 휘일 크레인의 조향 제어장치 | |
| US4219121A (en) | Safety system for use in association with material handling equipment | |
| EP2388228B1 (de) | Ausleger Teleskop-Steuereinheit | |
| EP0139054A1 (de) | Verfahren zum Steuern des Aus- und Einfahrens von mehrstufigen Teleskopauslegern | |
| JPH09216786A (ja) | 油圧クレーンのブーム伸縮停止保持装置 | |
| US4215622A (en) | Hydraulic control system | |
| US5791229A (en) | Control device for travelling system in construction vehicles | |
| JP3262422B2 (ja) | クレーン | |
| JP2003194012A (ja) | 油圧アクチュエータの切換制御弁 | |
| JPS6411558B2 (de) | ||
| KR940000245B1 (ko) | 중장비 작업장치의 파우어업제어장치 및 그 제어방법 | |
| JP2004189396A (ja) | クレーンの制御装置 | |
| JP3153972B2 (ja) | 単一可変容量ポンプによる複数アクチュエータの作動制御装置 | |
| JP2634301B2 (ja) | フルフリーマスト装置の昇降油圧制御方法 | |
| KR920006890Y1 (ko) | 유압크레인의 부움 자동신축장치 | |
| EP4253304B1 (de) | Arbeitsmaschine | |
| JP4707872B2 (ja) | 油圧アクチュエータの制御装置 | |
| JPH0625603U (ja) | マニュアル操作を併用した電子油圧制御回路 | |
| JPH0612123B2 (ja) | ウインチの操作力制御装置 |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| PUAI | Public reference made under article 153(3) epc to a published international application that has entered the european phase |
Free format text: ORIGINAL CODE: 0009012 |
|
| 17P | Request for examination filed |
Effective date: 19831107 |
|
| AK | Designated contracting states |
Designated state(s): DE FR GB NL |
|
| 17Q | First examination report despatched |
Effective date: 19860121 |
|
| GRAA | (expected) grant |
Free format text: ORIGINAL CODE: 0009210 |
|
| AK | Designated contracting states |
Kind code of ref document: B1 Designated state(s): DE FR GB NL |
|
| REF | Corresponds to: |
Ref document number: 3371900 Country of ref document: DE Date of ref document: 19870709 |
|
| ET | Fr: translation filed | ||
| PLBE | No opposition filed within time limit |
Free format text: ORIGINAL CODE: 0009261 |
|
| STAA | Information on the status of an ep patent application or granted ep patent |
Free format text: STATUS: NO OPPOSITION FILED WITHIN TIME LIMIT |
|
| 26N | No opposition filed | ||
| PGFP | Annual fee paid to national office [announced via postgrant information from national office to epo] |
Ref country code: FR Payment date: 19931011 Year of fee payment: 11 |
|
| PGFP | Annual fee paid to national office [announced via postgrant information from national office to epo] |
Ref country code: GB Payment date: 19931012 Year of fee payment: 11 |
|
| PGFP | Annual fee paid to national office [announced via postgrant information from national office to epo] |
Ref country code: DE Payment date: 19931021 Year of fee payment: 11 |
|
| PGFP | Annual fee paid to national office [announced via postgrant information from national office to epo] |
Ref country code: NL Payment date: 19931031 Year of fee payment: 11 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: GB Effective date: 19941021 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: NL Effective date: 19950501 |
|
| NLV4 | Nl: lapsed or anulled due to non-payment of the annual fee | ||
| GBPC | Gb: european patent ceased through non-payment of renewal fee |
Effective date: 19941021 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: FR Effective date: 19950630 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: DE Effective date: 19950701 |
|
| REG | Reference to a national code |
Ref country code: FR Ref legal event code: ST |