EP1894800A1 - Verfahren zum Ermitteln einer Neigung, auf die ein Kraftfahrzeug sich bewegt - Google Patents
Verfahren zum Ermitteln einer Neigung, auf die ein Kraftfahrzeug sich bewegt Download PDFInfo
- Publication number
- EP1894800A1 EP1894800A1 EP07112056A EP07112056A EP1894800A1 EP 1894800 A1 EP1894800 A1 EP 1894800A1 EP 07112056 A EP07112056 A EP 07112056A EP 07112056 A EP07112056 A EP 07112056A EP 1894800 A1 EP1894800 A1 EP 1894800A1
- Authority
- EP
- European Patent Office
- Prior art keywords
- vehicle
- slope
- speed
- wheels
- determining
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Granted
Links
Images

Classifications
-
- G—PHYSICS
- G01—MEASURING; TESTING
- G01G—WEIGHING
- G01G19/00—Weighing apparatus or methods adapted for special purposes not provided for in the preceding groups
- G01G19/08—Weighing apparatus or methods adapted for special purposes not provided for in the preceding groups for incorporation in vehicles
- G01G19/086—Weighing apparatus or methods adapted for special purposes not provided for in the preceding groups for incorporation in vehicles wherein the vehicle mass is dynamically estimated
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B60—VEHICLES IN GENERAL
- B60T—VEHICLE BRAKE CONTROL SYSTEMS OR PARTS THEREOF; BRAKE CONTROL SYSTEMS OR PARTS THEREOF, IN GENERAL; ARRANGEMENT OF BRAKING ELEMENTS ON VEHICLES IN GENERAL; PORTABLE DEVICES FOR PREVENTING UNWANTED MOVEMENT OF VEHICLES; VEHICLE MODIFICATIONS TO FACILITATE COOLING OF BRAKES
- B60T8/00—Arrangements for adjusting wheel-braking force to meet varying vehicular or ground-surface conditions, e.g. limiting or varying distribution of braking force
- B60T8/17—Using electrical or electronic regulation means to control braking
- B60T8/172—Determining control parameters used in the regulation, e.g. by calculations involving measured or detected parameters
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B60—VEHICLES IN GENERAL
- B60W—CONJOINT CONTROL OF VEHICLE SUB-UNITS OF DIFFERENT TYPE OR DIFFERENT FUNCTION; CONTROL SYSTEMS SPECIALLY ADAPTED FOR HYBRID VEHICLES; ROAD VEHICLE DRIVE CONTROL SYSTEMS FOR PURPOSES NOT RELATED TO THE CONTROL OF A PARTICULAR SUB-UNIT
- B60W40/00—Estimation or calculation of non-directly measurable driving parameters for road vehicle drive control systems not related to the control of a particular sub unit, e.g. by using mathematical models
- B60W40/02—Estimation or calculation of non-directly measurable driving parameters for road vehicle drive control systems not related to the control of a particular sub unit, e.g. by using mathematical models related to ambient conditions
- B60W40/06—Road conditions
- B60W40/076—Slope angle of the road
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B60—VEHICLES IN GENERAL
- B60W—CONJOINT CONTROL OF VEHICLE SUB-UNITS OF DIFFERENT TYPE OR DIFFERENT FUNCTION; CONTROL SYSTEMS SPECIALLY ADAPTED FOR HYBRID VEHICLES; ROAD VEHICLE DRIVE CONTROL SYSTEMS FOR PURPOSES NOT RELATED TO THE CONTROL OF A PARTICULAR SUB-UNIT
- B60W40/00—Estimation or calculation of non-directly measurable driving parameters for road vehicle drive control systems not related to the control of a particular sub unit, e.g. by using mathematical models
- B60W40/12—Estimation or calculation of non-directly measurable driving parameters for road vehicle drive control systems not related to the control of a particular sub unit, e.g. by using mathematical models related to parameters of the vehicle itself, e.g. tyre models
- B60W40/13—Load or weight
-
- F—MECHANICAL ENGINEERING; LIGHTING; HEATING; WEAPONS; BLASTING
- F16—ENGINEERING ELEMENTS AND UNITS; GENERAL MEASURES FOR PRODUCING AND MAINTAINING EFFECTIVE FUNCTIONING OF MACHINES OR INSTALLATIONS; THERMAL INSULATION IN GENERAL
- F16H—GEARING
- F16H59/00—Control inputs to control units of change-speed- or reversing-gearings for conveying rotary motion
- F16H59/60—Inputs being a function of ambient conditions
- F16H59/66—Road conditions, e.g. slope, slippery
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B60—VEHICLES IN GENERAL
- B60G—VEHICLE SUSPENSION ARRANGEMENTS
- B60G2400/00—Indexing codes relating to detected, measured or calculated conditions or factors
- B60G2400/10—Acceleration; Deceleration
- B60G2400/106—Acceleration; Deceleration longitudinal with regard to vehicle, e.g. braking
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B60—VEHICLES IN GENERAL
- B60G—VEHICLE SUSPENSION ARRANGEMENTS
- B60G2400/00—Indexing codes relating to detected, measured or calculated conditions or factors
- B60G2400/80—Exterior conditions
- B60G2400/82—Ground surface
- B60G2400/824—Travel path sensing; Track monitoring
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B60—VEHICLES IN GENERAL
- B60G—VEHICLE SUSPENSION ARRANGEMENTS
- B60G2800/00—Indexing codes relating to the type of movement or to the condition of the vehicle and to the end result to be achieved by the control action
- B60G2800/01—Attitude or posture control
- B60G2800/019—Inclination due to load distribution or road gradient
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B60—VEHICLES IN GENERAL
- B60G—VEHICLE SUSPENSION ARRANGEMENTS
- B60G2800/00—Indexing codes relating to the type of movement or to the condition of the vehicle and to the end result to be achieved by the control action
- B60G2800/01—Attitude or posture control
- B60G2800/019—Inclination due to load distribution or road gradient
- B60G2800/0192—Inclination due to load distribution or road gradient longitudinal with regard to vehicle
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B60—VEHICLES IN GENERAL
- B60G—VEHICLE SUSPENSION ARRANGEMENTS
- B60G2800/00—Indexing codes relating to the type of movement or to the condition of the vehicle and to the end result to be achieved by the control action
- B60G2800/70—Estimating or calculating vehicle parameters or state variables
- B60G2800/702—Improving accuracy of a sensor signal
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B60—VEHICLES IN GENERAL
- B60G—VEHICLE SUSPENSION ARRANGEMENTS
- B60G2800/00—Indexing codes relating to the type of movement or to the condition of the vehicle and to the end result to be achieved by the control action
- B60G2800/90—System Controller type
- B60G2800/92—ABS - Brake Control
- B60G2800/922—EBV - Electronic brake force distribution
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B60—VEHICLES IN GENERAL
- B60T—VEHICLE BRAKE CONTROL SYSTEMS OR PARTS THEREOF; BRAKE CONTROL SYSTEMS OR PARTS THEREOF, IN GENERAL; ARRANGEMENT OF BRAKING ELEMENTS ON VEHICLES IN GENERAL; PORTABLE DEVICES FOR PREVENTING UNWANTED MOVEMENT OF VEHICLES; VEHICLE MODIFICATIONS TO FACILITATE COOLING OF BRAKES
- B60T2250/00—Monitoring, detecting, estimating vehicle conditions
- B60T2250/02—Vehicle mass
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B60—VEHICLES IN GENERAL
- B60W—CONJOINT CONTROL OF VEHICLE SUB-UNITS OF DIFFERENT TYPE OR DIFFERENT FUNCTION; CONTROL SYSTEMS SPECIALLY ADAPTED FOR HYBRID VEHICLES; ROAD VEHICLE DRIVE CONTROL SYSTEMS FOR PURPOSES NOT RELATED TO THE CONTROL OF A PARTICULAR SUB-UNIT
- B60W10/00—Conjoint control of vehicle sub-units of different type or different function
- B60W10/02—Conjoint control of vehicle sub-units of different type or different function including control of driveline clutches
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B60—VEHICLES IN GENERAL
- B60W—CONJOINT CONTROL OF VEHICLE SUB-UNITS OF DIFFERENT TYPE OR DIFFERENT FUNCTION; CONTROL SYSTEMS SPECIALLY ADAPTED FOR HYBRID VEHICLES; ROAD VEHICLE DRIVE CONTROL SYSTEMS FOR PURPOSES NOT RELATED TO THE CONTROL OF A PARTICULAR SUB-UNIT
- B60W10/00—Conjoint control of vehicle sub-units of different type or different function
- B60W10/18—Conjoint control of vehicle sub-units of different type or different function including control of braking systems
- B60W10/184—Conjoint control of vehicle sub-units of different type or different function including control of braking systems with wheel brakes
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B60—VEHICLES IN GENERAL
- B60W—CONJOINT CONTROL OF VEHICLE SUB-UNITS OF DIFFERENT TYPE OR DIFFERENT FUNCTION; CONTROL SYSTEMS SPECIALLY ADAPTED FOR HYBRID VEHICLES; ROAD VEHICLE DRIVE CONTROL SYSTEMS FOR PURPOSES NOT RELATED TO THE CONTROL OF A PARTICULAR SUB-UNIT
- B60W2520/00—Input parameters relating to overall vehicle dynamics
- B60W2520/10—Longitudinal speed
- B60W2520/105—Longitudinal acceleration
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B60—VEHICLES IN GENERAL
- B60W—CONJOINT CONTROL OF VEHICLE SUB-UNITS OF DIFFERENT TYPE OR DIFFERENT FUNCTION; CONTROL SYSTEMS SPECIALLY ADAPTED FOR HYBRID VEHICLES; ROAD VEHICLE DRIVE CONTROL SYSTEMS FOR PURPOSES NOT RELATED TO THE CONTROL OF A PARTICULAR SUB-UNIT
- B60W2552/00—Input parameters relating to infrastructure
- B60W2552/15—Road slope, i.e. the inclination of a road segment in the longitudinal direction
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B60—VEHICLES IN GENERAL
- B60W—CONJOINT CONTROL OF VEHICLE SUB-UNITS OF DIFFERENT TYPE OR DIFFERENT FUNCTION; CONTROL SYSTEMS SPECIALLY ADAPTED FOR HYBRID VEHICLES; ROAD VEHICLE DRIVE CONTROL SYSTEMS FOR PURPOSES NOT RELATED TO THE CONTROL OF A PARTICULAR SUB-UNIT
- B60W2710/00—Output or target parameters relating to a particular sub-units
- B60W2710/18—Braking system
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B60—VEHICLES IN GENERAL
- B60W—CONJOINT CONTROL OF VEHICLE SUB-UNITS OF DIFFERENT TYPE OR DIFFERENT FUNCTION; CONTROL SYSTEMS SPECIALLY ADAPTED FOR HYBRID VEHICLES; ROAD VEHICLE DRIVE CONTROL SYSTEMS FOR PURPOSES NOT RELATED TO THE CONTROL OF A PARTICULAR SUB-UNIT
- B60W30/00—Purposes of road vehicle drive control systems not related to the control of a particular sub-unit, e.g. of systems using conjoint control of vehicle sub-units
- B60W30/18—Propelling the vehicle
- B60W30/18172—Preventing, or responsive to skidding of wheels
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B60—VEHICLES IN GENERAL
- B60W—CONJOINT CONTROL OF VEHICLE SUB-UNITS OF DIFFERENT TYPE OR DIFFERENT FUNCTION; CONTROL SYSTEMS SPECIALLY ADAPTED FOR HYBRID VEHICLES; ROAD VEHICLE DRIVE CONTROL SYSTEMS FOR PURPOSES NOT RELATED TO THE CONTROL OF A PARTICULAR SUB-UNIT
- B60W40/00—Estimation or calculation of non-directly measurable driving parameters for road vehicle drive control systems not related to the control of a particular sub unit, e.g. by using mathematical models
- B60W40/02—Estimation or calculation of non-directly measurable driving parameters for road vehicle drive control systems not related to the control of a particular sub unit, e.g. by using mathematical models related to ambient conditions
- B60W40/06—Road conditions
- B60W40/072—Curvature of the road
Definitions
- the invention relates to a method for determining the slope of a car track on which a motor vehicle moves, the vehicle mass and the vehicle trajectory control device using the value of the mass thus determined.
- Today's motor vehicles are equipped with driver assistance systems such as anti-lock brakes (ABS), trajectory control (ESP) and / or anti-slip wheels (ASR) which are depending on the circumstances, may modulate the braking force applied to each wheel of the vehicle or generate a braking force.
- driver assistance systems such as anti-lock brakes (ABS), trajectory control (ESP) and / or anti-slip wheels (ASR) which are depending on the circumstances, may modulate the braking force applied to each wheel of the vehicle or generate a braking force.
- trajectory control systems are designed to estimate in real time and while driving the vehicle load, ie its total weight, to take account of the estimated load in the adjustment of the performed interventions. .
- the estimate of the load depends on the estimate of the slope of the roadway on which the vehicle is traveling and this slope estimate is currently not very precise, a known way being to equip the vehicle with a sensor of tilt, which has the disadvantage of increasing the cost of the system and its complexity.
- the object of the invention is to avoid these drawbacks by means of a method of determining the slope that is simple, effective and economical.
- This method allows a relatively accurate and fast determination of the slope of the roadway from information that is available and whose acquisition does not require the installation of an additional sensor.
- the variation of the speed of the vehicle on the slope is determined during a change of transmission ratio, during the time interval corresponding to the decoupling between the engine and the drive wheels.
- this method also consists in determining, advantageously by calculation, the mass of the vehicle traveling on the slope.
- this estimated value of the slope is then used to correct the estimated value of the vehicle load.
- the speed variation of the vehicle is determined on the basis of the information provided by the speedometer of this vehicle, or advantageously by the sensors for the speed of rotation of the wheels.
- the method also includes determining when the engine is decoupled from the drive wheels from information provided by the computer of the ESP trajectory control device, the engine injection computer or other.
- the subject of the present invention is also a vehicle comprising a motor, a clutch (E), wheels and means for controlling the speed of rotation of the wheels, characterized in that it comprises means for measuring the slope ⁇ of the vehicle. by measuring the acceleration ⁇ of the vehicle traveling on said slope, with the engine disengaged.
- the present invention also relates to a vehicle characterized in that it comprises means for determining the mass m of the vehicle as a function of the slope measured.
- the present invention also relates to a vehicle characterized in that it comprises a hydraulic control unit of hydraulic brakes arranged at the wheels ensuring the individual reduction in the speed of rotation of the wheels when it exceeds the desired speed so that the vehicle follows the path desired by the driver.
- reference numeral 10 designates, in general terms, a motor vehicle whose internal combustion engine 12 drives, via a clutch E, connecting its output shaft 14 to the input shaft 16. a gearbox 18 and a transmission 20, the wheels 22 of the vehicle.
- the means for determining the slope comprise information processing means 24, which receives as input a vehicle speed signal 26 supplied by a wheel rotation speed sensor 22, a signal 34 opening of the clutch, provided by transmission ratio changing means 36 (which can be controlled by the driver of the vehicle or which can be automated) in the case of a robotized gearbox) and / or a speed signal 38 of the output shaft of the motor, provided by a suitable sensor 40.
- information processing means 24 which receives as input a vehicle speed signal 26 supplied by a wheel rotation speed sensor 22, a signal 34 opening of the clutch, provided by transmission ratio changing means 36 (which can be controlled by the driver of the vehicle or which can be automated) in the case of a robotized gearbox) and / or a speed signal 38 of the output shaft of the motor, provided by a suitable sensor 40.
- the ESP computer also associated with a hydraulic unit provided, in known manner, with a hydraulic pump and valves connected to the brakes, plays the role of the means 24 for processing information.
- the determination of a time interval during which the engine is decoupled from the driving wheels can be done either from the information relating to the state of the transmission ratio changing means 36 or by comparing the speed 26 of the vehicle and the speed of rotation of the engine, a non-linear ratio of variation of these two speeds indicating that the engine is decoupled from the driving wheels of the vehicle.
- the variation of the speed of the vehicle during the time interval when the clutch E is open, is a data which makes it possible to calculate the slope of the roadway on which the vehicle moves.
- the sum of the forces is equal to the sum of the rolling resistance F roll drag, the aerodynamic drag Aero and the force F slope resulting from the acceleration of the gravity on a slope of angle ⁇ with respect to the horizontal .
- F mg K roll g being equal to 9.8 ms -2
- K roll is a vehicle constant that can be measured during vehicle design.
- the slope ⁇ is determined by comparing the measured values with the values of a calibration table similar to Table 1 but including information on all the slopes that may have to be measured.
- the actual value of the tread opposing the advance of the vehicle is deduced from the mass in order to increase the value of the braking torque for the brakes up to the actual limit of slippage.
- the stopping distances of the vehicle are reduced.
- the intervention threshold of the ESP trajectory control device is optimized in a low adhesion curve, for example on wet or icy ground.
- the thresholds of the ESP are modified as a function of the mass of the vehicle.
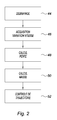
- the first step 44 is the detection of a clutch.
- the next step 46 includes acquiring the variation of the vehicle speed during the time interval when the engine is disengaged. For example, it is possible to measure the speed of the vehicle at two different times and to divide the speed difference by the time interval between these two instants or to proceed by derivation of the vehicle speed signal.
- step 48 consists of a calculation of the slope ⁇ .
- the corrected value of the load is then taken into account by the ABS, ESP and ASR type systems for an adjustment of their interventions 52.
Landscapes
- Engineering & Computer Science (AREA)
- Mechanical Engineering (AREA)
- Physics & Mathematics (AREA)
- Transportation (AREA)
- General Engineering & Computer Science (AREA)
- Automation & Control Theory (AREA)
- Mathematical Physics (AREA)
- General Physics & Mathematics (AREA)
- Regulating Braking Force (AREA)
- Control Of Driving Devices And Active Controlling Of Vehicle (AREA)
- Hydraulic Control Valves For Brake Systems (AREA)
- Vehicle Step Arrangements And Article Storage (AREA)
- Hydraulic Clutches, Magnetic Clutches, Fluid Clutches, And Fluid Joints (AREA)
- Control Of Transmission Device (AREA)
- Control Of Vehicles With Linear Motors And Vehicles That Are Magnetically Levitated (AREA)
- Train Traffic Observation, Control, And Security (AREA)
- Vehicle Body Suspensions (AREA)
Priority Applications (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| PL07112056T PL1894800T3 (pl) | 2006-08-28 | 2007-07-09 | Pojazd posiadający środki do określania pochyłości, po której się porusza |
Applications Claiming Priority (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| FR0607603A FR2905107B1 (fr) | 2006-08-28 | 2006-08-28 | Procede de controle de trajectoire d'un vehicule. |
Publications (2)
| Publication Number | Publication Date |
|---|---|
| EP1894800A1 true EP1894800A1 (de) | 2008-03-05 |
| EP1894800B1 EP1894800B1 (de) | 2010-12-08 |
Family
ID=37900756
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| EP07112056A Active EP1894800B1 (de) | 2006-08-28 | 2007-07-09 | Fahrzeug mit Mitteln zum Ermitteln einer Neigung, auf die es sich bewegt |
Country Status (9)
| Country | Link |
|---|---|
| US (1) | US8024100B2 (de) |
| EP (1) | EP1894800B1 (de) |
| JP (1) | JP5237599B2 (de) |
| AT (1) | ATE490896T1 (de) |
| DE (1) | DE602007011010D1 (de) |
| ES (1) | ES2355801T3 (de) |
| FR (1) | FR2905107B1 (de) |
| PL (1) | PL1894800T3 (de) |
| PT (1) | PT1894800E (de) |
Cited By (3)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN103661352A (zh) * | 2012-08-31 | 2014-03-26 | 福特全球技术公司 | 静态道路坡度估计 |
| US10042815B2 (en) | 2012-08-31 | 2018-08-07 | Ford Global Technologies, Llc | Road gradient estimation arbitration |
| CN109017776A (zh) * | 2017-06-08 | 2018-12-18 | 丰田自动车株式会社 | 安装在车辆中的驾驶辅助系统 |
Families Citing this family (4)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JP2008162380A (ja) * | 2006-12-27 | 2008-07-17 | Fujitsu Ten Ltd | 加速度評価装置 |
| JP5652090B2 (ja) | 2010-09-30 | 2015-01-14 | トヨタ自動車株式会社 | 車両制御装置 |
| US9616898B2 (en) * | 2013-12-12 | 2017-04-11 | Ford Global Technologies, Llc | System and method for determining effective road grade characteristic |
| JP2014238101A (ja) * | 2014-09-26 | 2014-12-18 | トヨタ自動車株式会社 | 車両制御装置 |
Citations (3)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| DE4446358C1 (de) * | 1994-12-23 | 1995-12-07 | Knorr Bremse Systeme | Verfahren und Anordnung zum Einstellen der Bremskraftaufteilung zwischen einem Zugfahrzeug und dem Anhänger |
| EP1387153A1 (de) * | 2002-08-03 | 2004-02-04 | Robert Bosch Gmbh | Verfahren und Vorrichtung zur Ermittlung der Fahrzeugmasse |
| DE10245270A1 (de) * | 2002-09-27 | 2004-04-01 | Robert Bosch Gmbh | Verfahren und Vorrichtung zur Bestimmung der Masse eines Kraftfahrzeugs |
Family Cites Families (4)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| DE19511897C2 (de) * | 1995-03-31 | 1999-06-02 | Daimler Chrysler Ag | Verfahren zum Steuern einer ein- und ausrückbaren Reibschlußverbindung bei einer Schaltungsvorrichtung eines automatischen Stufengetriebes eines Kraftfahrzeuges |
| DE19728769A1 (de) * | 1997-07-05 | 1999-01-07 | Bosch Gmbh Robert | Verfahren und Vorrichtung zur Ermittlung der Fahrzeugmasse |
| US6167357A (en) * | 1998-04-23 | 2000-12-26 | Cummins Engine Company, Inc. | Recursive vehicle mass estimation |
| SE519792C2 (sv) * | 2001-08-17 | 2003-04-08 | Volvo Lastvagnar Ab | Metod för estimering av massan hos ett fordon vilket framförs på en väg med en varierande lutning samt metod för estimering av lutningen av den väg där ett fordon framförs |
-
2006
- 2006-08-28 FR FR0607603A patent/FR2905107B1/fr not_active Expired - Fee Related
-
2007
- 2007-07-09 ES ES07112056T patent/ES2355801T3/es active Active
- 2007-07-09 PT PT07112056T patent/PT1894800E/pt unknown
- 2007-07-09 DE DE602007011010T patent/DE602007011010D1/de active Active
- 2007-07-09 PL PL07112056T patent/PL1894800T3/pl unknown
- 2007-07-09 EP EP07112056A patent/EP1894800B1/de active Active
- 2007-07-09 AT AT07112056T patent/ATE490896T1/de not_active IP Right Cessation
- 2007-08-10 US US11/837,018 patent/US8024100B2/en not_active Expired - Fee Related
- 2007-08-27 JP JP2007219268A patent/JP5237599B2/ja active Active
Patent Citations (3)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| DE4446358C1 (de) * | 1994-12-23 | 1995-12-07 | Knorr Bremse Systeme | Verfahren und Anordnung zum Einstellen der Bremskraftaufteilung zwischen einem Zugfahrzeug und dem Anhänger |
| EP1387153A1 (de) * | 2002-08-03 | 2004-02-04 | Robert Bosch Gmbh | Verfahren und Vorrichtung zur Ermittlung der Fahrzeugmasse |
| DE10245270A1 (de) * | 2002-09-27 | 2004-04-01 | Robert Bosch Gmbh | Verfahren und Vorrichtung zur Bestimmung der Masse eines Kraftfahrzeugs |
Cited By (4)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN103661352A (zh) * | 2012-08-31 | 2014-03-26 | 福特全球技术公司 | 静态道路坡度估计 |
| US10042815B2 (en) | 2012-08-31 | 2018-08-07 | Ford Global Technologies, Llc | Road gradient estimation arbitration |
| CN109017776A (zh) * | 2017-06-08 | 2018-12-18 | 丰田自动车株式会社 | 安装在车辆中的驾驶辅助系统 |
| CN109017776B (zh) * | 2017-06-08 | 2021-08-20 | 丰田自动车株式会社 | 安装在车辆中的驾驶辅助系统 |
Also Published As
| Publication number | Publication date |
|---|---|
| PT1894800E (pt) | 2011-02-03 |
| ATE490896T1 (de) | 2010-12-15 |
| PL1894800T3 (pl) | 2011-05-31 |
| EP1894800B1 (de) | 2010-12-08 |
| FR2905107A1 (fr) | 2008-02-29 |
| JP5237599B2 (ja) | 2013-07-17 |
| DE602007011010D1 (de) | 2011-01-20 |
| US8024100B2 (en) | 2011-09-20 |
| US20080051966A1 (en) | 2008-02-28 |
| FR2905107B1 (fr) | 2009-03-27 |
| JP2008102121A (ja) | 2008-05-01 |
| ES2355801T3 (es) | 2011-03-31 |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| EP1642096B1 (de) | Verfahren und einrichtung zur schätzung der gesamtmasse eines kraftfahrzeugs | |
| EP3452792B1 (de) | Verfahren und vorrichtung zur bestimmung einer schätzung der gesamtmasse eines kraftfahrzeugs | |
| EP1894800B1 (de) | Fahrzeug mit Mitteln zum Ermitteln einer Neigung, auf die es sich bewegt | |
| EP2895826B1 (de) | Vorrichtung und verfahren zur schätzung der ladung eines kraftfahrzeugs | |
| FR2765682A1 (fr) | Procede et dispositif pour determiner la masse d'un vehicule | |
| EP2758257B1 (de) | Verfahren zur schätzung des rollwiderstandes eines fahrzeugrades | |
| FR2914894A1 (fr) | Systeme d'aide a la conduite dans les pentes pour vehicule automobile | |
| EP2021216A1 (de) | Vorrichtung und verfahren zur steuerung der leistung eines fahrzeugs mit vierradantrieb | |
| EP2157002A1 (de) | Verfahren zur Bestimmung des Schwimmwinkels eines Kraftfahrzeugs | |
| FR2920047A3 (fr) | Estimation de la pente de la route depuis un vehicule | |
| EP0919814B1 (de) | Verfahren zur Abschätzung der Geschwindigkeit eines Fahrzeuges oder mehrerer miteinander verbundener Fahrzeuge | |
| EP2082939B1 (de) | Verfahren und System zur Abschätzung der Haftung in einem Kraftfahrzeug | |
| FR2935807A1 (fr) | Procede de detection de l'arret d'un vehicule automobile | |
| WO2002032733A1 (fr) | Dispositif et procede pour detecter l'adherence d'un pneumatique de vehicule sur le sol | |
| EP3080565B1 (de) | Vorrichtung und verfahren zur schätzung der gesamtmasse eines kraftfahrzeugs mit fahrzeuginterner kalibrierung von aufhängungsverlagerungssensoren | |
| EP4343287B1 (de) | Verfahren und system zur bestimmung der masse eines fahrzeugs | |
| FR2932878A1 (fr) | Dispositif et procede de l'estimation de la pente du terrain pour le roulage d'un vehicule automobile. | |
| FR2922026A3 (fr) | Procede d'estimation de la vitesse longitudinale d'un vehicule automobile | |
| WO2007045787A1 (fr) | Procede de validation de la mesure fournie par un accelerometre dans un vehicule automobile et application a l’estimation de la pente | |
| FR2886264A1 (fr) | Indicateur de freinage pour vehicule automobile et vehicule automobile associe. | |
| EP1940662A1 (de) | Verfahren zur bestimmung des zustandes von kraftfahrzeugreifen und vorrichtung dafür | |
| FR2932892A1 (fr) | Dispositif et procede d'estimation de la vitesse d'un vehicule. | |
| EP1982888A1 (de) | Verfahren zur Stabilitätsregelung mit geschlossenem Regelkreis für ein Kraftfahrzeug | |
| FR2862930A1 (fr) | Systeme et procede de commande de l'acceleration d'un vehicule automobile dans une pente | |
| EP1938112A1 (de) | Einrichtung zur beschleunigungsmessung in einem kraftfahrzeug |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| PUAI | Public reference made under article 153(3) epc to a published international application that has entered the european phase |
Free format text: ORIGINAL CODE: 0009012 |
|
| AK | Designated contracting states |
Kind code of ref document: A1 Designated state(s): AT BE BG CH CY CZ DE DK EE ES FI FR GB GR HU IE IS IT LI LT LU LV MC MT NL PL PT RO SE SI SK TR |
|
| AX | Request for extension of the european patent |
Extension state: AL BA HR MK YU |
|
| 17P | Request for examination filed |
Effective date: 20080905 |
|
| AKX | Designation fees paid |
Designated state(s): AT BE BG CH CY CZ DE DK EE ES FI FR GB GR HU IE IS IT LI LT LU LV MC MT NL PL PT RO SE SI SK TR |
|
| 17Q | First examination report despatched |
Effective date: 20081106 |
|
| GRAP | Despatch of communication of intention to grant a patent |
Free format text: ORIGINAL CODE: EPIDOSNIGR1 |
|
| RTI1 | Title (correction) |
Free format text: VEHICLE COMPRISING MEANS FOR DETERMINING THE SLOPE ON WHICH IT MOVES |
|
| GRAS | Grant fee paid |
Free format text: ORIGINAL CODE: EPIDOSNIGR3 |
|
| GRAA | (expected) grant |
Free format text: ORIGINAL CODE: 0009210 |
|
| AK | Designated contracting states |
Kind code of ref document: B1 Designated state(s): AT BE BG CH CY CZ DE DK EE ES FI FR GB GR HU IE IS IT LI LT LU LV MC MT NL PL PT RO SE SI SK TR |
|
| REG | Reference to a national code |
Ref country code: GB Ref legal event code: FG4D Free format text: NOT ENGLISH |
|
| REG | Reference to a national code |
Ref country code: CH Ref legal event code: EP |
|
| REG | Reference to a national code |
Ref country code: IE Ref legal event code: FG4D |
|
| REF | Corresponds to: |
Ref document number: 602007011010 Country of ref document: DE Date of ref document: 20110120 Kind code of ref document: P |
|
| REG | Reference to a national code |
Ref country code: PT Ref legal event code: SC4A Free format text: AVAILABILITY OF NATIONAL TRANSLATION Effective date: 20110127 |
|
| REG | Reference to a national code |
Ref country code: NL Ref legal event code: VDEP Effective date: 20101208 |
|
| REG | Reference to a national code |
Ref country code: ES Ref legal event code: FG2A Ref document number: 2355801 Country of ref document: ES Kind code of ref document: T3 Effective date: 20110331 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: LT Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20101208 |
|
| LTIE | Lt: invalidation of european patent or patent extension |
Effective date: 20101208 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: NL Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20101208 Ref country code: BG Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20110308 Ref country code: SE Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20101208 Ref country code: AT Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20101208 Ref country code: FI Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20101208 Ref country code: LV Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20101208 Ref country code: CY Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20101208 Ref country code: SI Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20101208 |
|
| REG | Reference to a national code |
Ref country code: PL Ref legal event code: T3 |
|
| REG | Reference to a national code |
Ref country code: IE Ref legal event code: FD4D |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: IS Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20110408 Ref country code: IE Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20101208 Ref country code: GR Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20110309 Ref country code: EE Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20101208 Ref country code: CZ Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20101208 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: RO Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20101208 Ref country code: SK Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20101208 |
|
| PLBE | No opposition filed within time limit |
Free format text: ORIGINAL CODE: 0009261 |
|
| STAA | Information on the status of an ep patent application or granted ep patent |
Free format text: STATUS: NO OPPOSITION FILED WITHIN TIME LIMIT |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: DK Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20101208 |
|
| 26N | No opposition filed |
Effective date: 20110909 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: MT Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20101208 |
|
| REG | Reference to a national code |
Ref country code: DE Ref legal event code: R097 Ref document number: 602007011010 Country of ref document: DE Effective date: 20110909 |
|
| BERE | Be: lapsed |
Owner name: ROBERT BOSCH G.M.B.H. Effective date: 20110731 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: MC Free format text: LAPSE BECAUSE OF NON-PAYMENT OF DUE FEES Effective date: 20110731 |
|
| REG | Reference to a national code |
Ref country code: CH Ref legal event code: PL |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: LI Free format text: LAPSE BECAUSE OF NON-PAYMENT OF DUE FEES Effective date: 20110731 Ref country code: BE Free format text: LAPSE BECAUSE OF NON-PAYMENT OF DUE FEES Effective date: 20110731 Ref country code: CH Free format text: LAPSE BECAUSE OF NON-PAYMENT OF DUE FEES Effective date: 20110731 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: LU Free format text: LAPSE BECAUSE OF NON-PAYMENT OF DUE FEES Effective date: 20110709 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: HU Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20101208 |
|
| PGFP | Annual fee paid to national office [announced via postgrant information from national office to epo] |
Ref country code: ES Payment date: 20130722 Year of fee payment: 7 |
|
| PGFP | Annual fee paid to national office [announced via postgrant information from national office to epo] |
Ref country code: FR Payment date: 20130719 Year of fee payment: 7 Ref country code: GB Payment date: 20130723 Year of fee payment: 7 |
|
| GBPC | Gb: european patent ceased through non-payment of renewal fee |
Effective date: 20140709 |
|
| REG | Reference to a national code |
Ref country code: FR Ref legal event code: ST Effective date: 20150331 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: GB Free format text: LAPSE BECAUSE OF NON-PAYMENT OF DUE FEES Effective date: 20140709 Ref country code: FR Free format text: LAPSE BECAUSE OF NON-PAYMENT OF DUE FEES Effective date: 20140731 |
|
| REG | Reference to a national code |
Ref country code: ES Ref legal event code: FD2A Effective date: 20160129 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: ES Free format text: LAPSE BECAUSE OF NON-PAYMENT OF DUE FEES Effective date: 20140710 |
|
| PGFP | Annual fee paid to national office [announced via postgrant information from national office to epo] |
Ref country code: TR Payment date: 20170706 Year of fee payment: 11 |
|
| PGFP | Annual fee paid to national office [announced via postgrant information from national office to epo] |
Ref country code: PT Payment date: 20190627 Year of fee payment: 13 |
|
| PGFP | Annual fee paid to national office [announced via postgrant information from national office to epo] |
Ref country code: PL Payment date: 20190704 Year of fee payment: 13 |
|
| PGFP | Annual fee paid to national office [announced via postgrant information from national office to epo] |
Ref country code: IT Payment date: 20200731 Year of fee payment: 14 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: PT Free format text: LAPSE BECAUSE OF NON-PAYMENT OF DUE FEES Effective date: 20210211 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: TR Free format text: LAPSE BECAUSE OF NON-PAYMENT OF DUE FEES Effective date: 20200709 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: IT Free format text: LAPSE BECAUSE OF NON-PAYMENT OF DUE FEES Effective date: 20210709 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: PL Free format text: LAPSE BECAUSE OF NON-PAYMENT OF DUE FEES Effective date: 20200709 |
|
| PGFP | Annual fee paid to national office [announced via postgrant information from national office to epo] |
Ref country code: DE Payment date: 20250924 Year of fee payment: 19 |