EP2660478B1 - Hydraulisches steuersystem eines auslegerdrehgelenkverbundantriebs einer einer baumaschine - Google Patents
Hydraulisches steuersystem eines auslegerdrehgelenkverbundantriebs einer einer baumaschine Download PDFInfo
- Publication number
- EP2660478B1 EP2660478B1 EP10861359.7A EP10861359A EP2660478B1 EP 2660478 B1 EP2660478 B1 EP 2660478B1 EP 10861359 A EP10861359 A EP 10861359A EP 2660478 B1 EP2660478 B1 EP 2660478B1
- Authority
- EP
- European Patent Office
- Prior art keywords
- boom
- control valve
- hydraulic
- flow rate
- spool
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Not-in-force
Links
- 238000010276 construction Methods 0.000 title claims description 17
- 150000001875 compounds Chemical class 0.000 title 1
- 239000012530 fluid Substances 0.000 claims description 32
- 238000006073 displacement reaction Methods 0.000 claims description 6
- 238000009412 basement excavation Methods 0.000 description 5
- 238000010586 diagram Methods 0.000 description 2
- 230000000694 effects Effects 0.000 description 2
- 230000006866 deterioration Effects 0.000 description 1
- 230000004048 modification Effects 0.000 description 1
- 238000012986 modification Methods 0.000 description 1
- 239000013643 reference control Substances 0.000 description 1
Images
Classifications
-
- F—MECHANICAL ENGINEERING; LIGHTING; HEATING; WEAPONS; BLASTING
- F15—FLUID-PRESSURE ACTUATORS; HYDRAULICS OR PNEUMATICS IN GENERAL
- F15B—SYSTEMS ACTING BY MEANS OF FLUIDS IN GENERAL; FLUID-PRESSURE ACTUATORS, e.g. SERVOMOTORS; DETAILS OF FLUID-PRESSURE SYSTEMS, NOT OTHERWISE PROVIDED FOR
- F15B13/00—Details of servomotor systems ; Valves for servomotor systems
- F15B13/02—Fluid distribution or supply devices characterised by their adaptation to the control of servomotors
-
- E—FIXED CONSTRUCTIONS
- E02—HYDRAULIC ENGINEERING; FOUNDATIONS; SOIL SHIFTING
- E02F—DREDGING; SOIL-SHIFTING
- E02F9/00—Component parts of dredgers or soil-shifting machines, not restricted to one of the kinds covered by groups E02F3/00 - E02F7/00
- E02F9/20—Drives; Control devices
- E02F9/22—Hydraulic or pneumatic drives
- E02F9/2278—Hydraulic circuits
- E02F9/2292—Systems with two or more pumps
-
- E—FIXED CONSTRUCTIONS
- E02—HYDRAULIC ENGINEERING; FOUNDATIONS; SOIL SHIFTING
- E02F—DREDGING; SOIL-SHIFTING
- E02F9/00—Component parts of dredgers or soil-shifting machines, not restricted to one of the kinds covered by groups E02F3/00 - E02F7/00
- E02F9/20—Drives; Control devices
- E02F9/2025—Particular purposes of control systems not otherwise provided for
- E02F9/2037—Coordinating the movements of the implement and of the frame
-
- E—FIXED CONSTRUCTIONS
- E02—HYDRAULIC ENGINEERING; FOUNDATIONS; SOIL SHIFTING
- E02F—DREDGING; SOIL-SHIFTING
- E02F9/00—Component parts of dredgers or soil-shifting machines, not restricted to one of the kinds covered by groups E02F3/00 - E02F7/00
- E02F9/20—Drives; Control devices
- E02F9/22—Hydraulic or pneumatic drives
- E02F9/2221—Control of flow rate; Load sensing arrangements
- E02F9/2239—Control of flow rate; Load sensing arrangements using two or more pumps with cross-assistance
- E02F9/2242—Control of flow rate; Load sensing arrangements using two or more pumps with cross-assistance including an electronic controller
-
- E—FIXED CONSTRUCTIONS
- E02—HYDRAULIC ENGINEERING; FOUNDATIONS; SOIL SHIFTING
- E02F—DREDGING; SOIL-SHIFTING
- E02F9/00—Component parts of dredgers or soil-shifting machines, not restricted to one of the kinds covered by groups E02F3/00 - E02F7/00
- E02F9/20—Drives; Control devices
- E02F9/22—Hydraulic or pneumatic drives
- E02F9/2278—Hydraulic circuits
- E02F9/2296—Systems with a variable displacement pump
-
- F—MECHANICAL ENGINEERING; LIGHTING; HEATING; WEAPONS; BLASTING
- F15—FLUID-PRESSURE ACTUATORS; HYDRAULICS OR PNEUMATICS IN GENERAL
- F15B—SYSTEMS ACTING BY MEANS OF FLUIDS IN GENERAL; FLUID-PRESSURE ACTUATORS, e.g. SERVOMOTORS; DETAILS OF FLUID-PRESSURE SYSTEMS, NOT OTHERWISE PROVIDED FOR
- F15B11/00—Servomotor systems without provision for follow-up action; Circuits therefor
- F15B11/16—Servomotor systems without provision for follow-up action; Circuits therefor with two or more servomotors
- F15B11/17—Servomotor systems without provision for follow-up action; Circuits therefor with two or more servomotors using two or more pumps
-
- F—MECHANICAL ENGINEERING; LIGHTING; HEATING; WEAPONS; BLASTING
- F15—FLUID-PRESSURE ACTUATORS; HYDRAULICS OR PNEUMATICS IN GENERAL
- F15B—SYSTEMS ACTING BY MEANS OF FLUIDS IN GENERAL; FLUID-PRESSURE ACTUATORS, e.g. SERVOMOTORS; DETAILS OF FLUID-PRESSURE SYSTEMS, NOT OTHERWISE PROVIDED FOR
- F15B13/00—Details of servomotor systems ; Valves for servomotor systems
- F15B13/02—Fluid distribution or supply devices characterised by their adaptation to the control of servomotors
- F15B13/04—Fluid distribution or supply devices characterised by their adaptation to the control of servomotors for use with a single servomotor
- F15B13/044—Fluid distribution or supply devices characterised by their adaptation to the control of servomotors for use with a single servomotor operated by electrically-controlled means, e.g. solenoids, torque-motors
-
- F—MECHANICAL ENGINEERING; LIGHTING; HEATING; WEAPONS; BLASTING
- F15—FLUID-PRESSURE ACTUATORS; HYDRAULICS OR PNEUMATICS IN GENERAL
- F15B—SYSTEMS ACTING BY MEANS OF FLUIDS IN GENERAL; FLUID-PRESSURE ACTUATORS, e.g. SERVOMOTORS; DETAILS OF FLUID-PRESSURE SYSTEMS, NOT OTHERWISE PROVIDED FOR
- F15B2211/00—Circuits for servomotor systems
- F15B2211/20—Fluid pressure source, e.g. accumulator or variable axial piston pump
- F15B2211/205—Systems with pumps
- F15B2211/2053—Type of pump
- F15B2211/20546—Type of pump variable capacity
-
- F—MECHANICAL ENGINEERING; LIGHTING; HEATING; WEAPONS; BLASTING
- F15—FLUID-PRESSURE ACTUATORS; HYDRAULICS OR PNEUMATICS IN GENERAL
- F15B—SYSTEMS ACTING BY MEANS OF FLUIDS IN GENERAL; FLUID-PRESSURE ACTUATORS, e.g. SERVOMOTORS; DETAILS OF FLUID-PRESSURE SYSTEMS, NOT OTHERWISE PROVIDED FOR
- F15B2211/00—Circuits for servomotor systems
- F15B2211/20—Fluid pressure source, e.g. accumulator or variable axial piston pump
- F15B2211/205—Systems with pumps
- F15B2211/20576—Systems with pumps with multiple pumps
-
- F—MECHANICAL ENGINEERING; LIGHTING; HEATING; WEAPONS; BLASTING
- F15—FLUID-PRESSURE ACTUATORS; HYDRAULICS OR PNEUMATICS IN GENERAL
- F15B—SYSTEMS ACTING BY MEANS OF FLUIDS IN GENERAL; FLUID-PRESSURE ACTUATORS, e.g. SERVOMOTORS; DETAILS OF FLUID-PRESSURE SYSTEMS, NOT OTHERWISE PROVIDED FOR
- F15B2211/00—Circuits for servomotor systems
- F15B2211/30—Directional control
- F15B2211/305—Directional control characterised by the type of valves
- F15B2211/3056—Assemblies of multiple valves
- F15B2211/3059—Assemblies of multiple valves having multiple valves for multiple output members
- F15B2211/30595—Assemblies of multiple valves having multiple valves for multiple output members with additional valves between the groups of valves for multiple output members
-
- F—MECHANICAL ENGINEERING; LIGHTING; HEATING; WEAPONS; BLASTING
- F15—FLUID-PRESSURE ACTUATORS; HYDRAULICS OR PNEUMATICS IN GENERAL
- F15B—SYSTEMS ACTING BY MEANS OF FLUIDS IN GENERAL; FLUID-PRESSURE ACTUATORS, e.g. SERVOMOTORS; DETAILS OF FLUID-PRESSURE SYSTEMS, NOT OTHERWISE PROVIDED FOR
- F15B2211/00—Circuits for servomotor systems
- F15B2211/40—Flow control
- F15B2211/405—Flow control characterised by the type of flow control means or valve
- F15B2211/40515—Flow control characterised by the type of flow control means or valve with variable throttles or orifices
-
- F—MECHANICAL ENGINEERING; LIGHTING; HEATING; WEAPONS; BLASTING
- F15—FLUID-PRESSURE ACTUATORS; HYDRAULICS OR PNEUMATICS IN GENERAL
- F15B—SYSTEMS ACTING BY MEANS OF FLUIDS IN GENERAL; FLUID-PRESSURE ACTUATORS, e.g. SERVOMOTORS; DETAILS OF FLUID-PRESSURE SYSTEMS, NOT OTHERWISE PROVIDED FOR
- F15B2211/00—Circuits for servomotor systems
- F15B2211/40—Flow control
- F15B2211/415—Flow control characterised by the connections of the flow control means in the circuit
- F15B2211/41509—Flow control characterised by the connections of the flow control means in the circuit being connected to a pressure source and a directional control valve
-
- F—MECHANICAL ENGINEERING; LIGHTING; HEATING; WEAPONS; BLASTING
- F15—FLUID-PRESSURE ACTUATORS; HYDRAULICS OR PNEUMATICS IN GENERAL
- F15B—SYSTEMS ACTING BY MEANS OF FLUIDS IN GENERAL; FLUID-PRESSURE ACTUATORS, e.g. SERVOMOTORS; DETAILS OF FLUID-PRESSURE SYSTEMS, NOT OTHERWISE PROVIDED FOR
- F15B2211/00—Circuits for servomotor systems
- F15B2211/40—Flow control
- F15B2211/42—Flow control characterised by the type of actuation
- F15B2211/428—Flow control characterised by the type of actuation actuated by fluid pressure
-
- F—MECHANICAL ENGINEERING; LIGHTING; HEATING; WEAPONS; BLASTING
- F15—FLUID-PRESSURE ACTUATORS; HYDRAULICS OR PNEUMATICS IN GENERAL
- F15B—SYSTEMS ACTING BY MEANS OF FLUIDS IN GENERAL; FLUID-PRESSURE ACTUATORS, e.g. SERVOMOTORS; DETAILS OF FLUID-PRESSURE SYSTEMS, NOT OTHERWISE PROVIDED FOR
- F15B2211/00—Circuits for servomotor systems
- F15B2211/40—Flow control
- F15B2211/455—Control of flow in the feed line, i.e. meter-in control
-
- F—MECHANICAL ENGINEERING; LIGHTING; HEATING; WEAPONS; BLASTING
- F15—FLUID-PRESSURE ACTUATORS; HYDRAULICS OR PNEUMATICS IN GENERAL
- F15B—SYSTEMS ACTING BY MEANS OF FLUIDS IN GENERAL; FLUID-PRESSURE ACTUATORS, e.g. SERVOMOTORS; DETAILS OF FLUID-PRESSURE SYSTEMS, NOT OTHERWISE PROVIDED FOR
- F15B2211/00—Circuits for servomotor systems
- F15B2211/60—Circuit components or control therefor
- F15B2211/665—Methods of control using electronic components
- F15B2211/6658—Control using different modes, e.g. four-quadrant-operation, working mode and transportation mode
-
- F—MECHANICAL ENGINEERING; LIGHTING; HEATING; WEAPONS; BLASTING
- F15—FLUID-PRESSURE ACTUATORS; HYDRAULICS OR PNEUMATICS IN GENERAL
- F15B—SYSTEMS ACTING BY MEANS OF FLUIDS IN GENERAL; FLUID-PRESSURE ACTUATORS, e.g. SERVOMOTORS; DETAILS OF FLUID-PRESSURE SYSTEMS, NOT OTHERWISE PROVIDED FOR
- F15B2211/00—Circuits for servomotor systems
- F15B2211/70—Output members, e.g. hydraulic motors or cylinders or control therefor
- F15B2211/71—Multiple output members, e.g. multiple hydraulic motors or cylinders
- F15B2211/7142—Multiple output members, e.g. multiple hydraulic motors or cylinders the output members being arranged in multiple groups
Definitions
- the present invention relates to a hydraulic control system for a combined boom and swing operation of a construction machine such as an excavator. More particularly, the present invention relates to a hydraulic system for a construction machine, in which the driving speeds of the boom and the swing device are adjusted according to working conditions during a combined operation in which boom-up and swing manipulations are carried out to perform an excavating and loading work, thereby ensuring a smooth work.
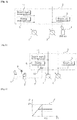
- a conventional hydraulic control system for a combined boom and swing operation of a construction machine in accordance with the prior art as shown in Fig. 1 includes:
- a non-explained reference numeral 11 denotes a boom confluence spool that allows the hydraulic fluid discharged from the first hydraulic pump 1 to join the hydraulic fluid discharged from the second hydraulic pump 2 when a boom-up operation is performed.
- an operator manipulates a boom manipulation lever 4 to shift a boom spool 5 and a boom confluence spool 11 so that the hydraulic fluid supplied to the boom cylinder via the boom spool 5 from the second hydraulic pump 2 and the hydraulic fluid supplied to the boom cylinder from the first hydraulic pump 1 via the boom confluence spool 11 join each other to cause the boom cylinder to be driven to perform a boom-up operation.
- an operator manipulates a manipulation lever (not shown) for the swing device to shift a swing spool 6 so that the hydraulic fluid supplied to the arm cylinder from the first hydraulic pump 1 via the swing spool 6 causes the swing device to be driven to swivel the upper swing structure.
- the hydraulic fluid discharged from the first hydraulic pump 1 is supplied to the boom cylinder via the boom spool 5 to drive the boom cylinder and the hydraulic fluid discharged from the first hydraulic pump 1 is distributingly supplied to the boom cylinder and the swing device, respectively, due to a difference in the pressure between the front ends of the boom confluence spool 11 and the swing spool 6.
- EP 1 672 128 A2 in accordance with the preamble of the independent claim, describes a hydraulic control device of an excavator for controlling combined operation of boom-raising and swing on a slope.
- a swing priority valve is provided on a pressured fluid supply line that connects a first hydraulic pump to a boom high-speed control valve. If an excavator performs its tasks on a slope, the swing priority valve is automatically shifted under a control of an electronic controller into a throttling position to thereby restrict hydraulic flow through the boom high-speed control valve so that an increased amount of hydraulic flow can be supplied to a swing motor, thus increasing a swing operating pressure more rapidly than a boom operating pressure and consequently facilitating combined operation of boom-raising and swing on a slope.
- JP H 09 3977 A describes a construction machine in which operation detecting signals are generated from a boom operation detecting switch, an arm operation detecting switch and a swing detecting switch on the basis of the operation of each joy stick, and input to an electronic control unit.
- the electronic control unit In the case where any one of each operation detecting signal is not generated, the electronic control unit outputs a predetermined reference current to an electromagnetic proportional pressure-reduction valve so that the reference control pressure is supplied to discharge flow rate control spools.
- the electronic control unit In the case where any one of the boom or the arm operation detecting signals is generated, the electronic
- control unit outputs a delay control current to the pressure-reduction valve so that a delay control pressure is supplied to the discharge capacity control spools. In the case where the swing detecting signal is generated, the control pressure is not supplied.
- JP 2002 047691 A describes a work vehicle with a mode switching means comprising a mode selector switch of work modes of one or more work machines.
- a speed fine control switch finely adjusting the work speed and/or travel speed set in each mode to the speed outside the range by a manual action is provided.;
- a flow adjusting valve arranged on drive circuits of an engine, pumps, one or more work machines and a travel motor is operated by the output signal via the operation of the speed fine control switch, and the engine speed and pump discharge quantity are adjusted.
- the optimum work mode of the work machine is effectively obtained according to the work contents and work conditions under implementation or the skill of an operator even in the environment that the work range is changed or an obstacle exists, and stable vehicle travelability and the operability of the work machine can be realized.
- the present invention was made to solve the aforementioned problem occurring in the prior art, and it is an object of the present invention to provide a hydraulic control system for a combined boom and swing operation of a construction machine, in which an operator can easily adjust the driving speeds of the boom and the swing device depending on various kinds of working conditions such as the excavation depth or the height of a dump vehicle during a combined operation in which the boom and the swing device are manipulated to smoothly perform an excavating and loading work.
- Another object of the present invention to provide a hydraulic control system for a combined boom and swing operation of a construction machine, in which in the case where an operator selects a certain work mode needed for the working conditions within an operator cab during the excavating and loading work, the flow rate of the hydraulic fluid distributed to a boom confluence spool and a swing spool is controlled depending on the selected work mode so that the driving speeds of the boom and the swing device can be adjusted under the working conditions needed by the operator.
- a hydraulic control system for a combined boom and swing operation of a construction machine which includes first and second variable displacement hydraulic pumps, an actuator for a swing device and a work apparatus, which is connected to the first hydraulic pump, an actuator for a work apparatus connected to the second hydraulic pump, and a flow rate control valve configured to control a low rate of a hydraulic fluid supplied respectively to the actuators for the swing device and the work apparatus from the first and second hydraulic pumps, the hydraulic control system including:
- the electronic proportional pressure control valve is mounted inside the flow rate control valve.
- the electronic proportional pressure control valve is mounted outside the flow rate control valve.
- variable flow rate control valve uses a variable orifice whose opening area is variably adjusted in proportion to the control signal pressure from the electronic proportional pressure control valve.
- the hydraulic control system for a combined boom and swing operation of a construction machine in accordance with an embodiment of the present invention as constructed above has the following advantages.
- An operator can easily adjust the driving speeds of the boom and the swing device depending on various kinds of working conditions such as the excavation depth or the height of a dump vehicle during a combined operation in which the boom and the swing device are manipulated to perform an excavating and loading work, thereby improving workability.
- the driving speeds of the boom and the swing device can be adjusted under the working conditions needed by the operator, thereby improving convenience of the operator.
- a hydraulic control system for a combined boom and swing operation of a construction machine in accordance with an embodiment of the present invention as shown in Fig. 2 includes first and second variable displacement hydraulic pumps, an actuator for a swing device and a work apparatus, which is connected to the first hydraulic pump, an actuator for a work apparatus connected to the second hydraulic pump, and a flow rate control valve configured to control a flow rate of a hydraulic fluid supplied respectively to the actuators for the swing device and the work apparatus from the first and second hydraulic pumps.
- the hydraulic control system includes:
- the electronic proportional pressure control valve 9 is mounted inside the flow rate control valve (MCV) 3.
- the electronic proportional pressure control valve 9 may be constructed as an electro proportional pressure reducing valve (EPPRV), and may be mounted inside the flow rate control valve (MCV) 3.
- EPPRV electro proportional pressure reducing valve
- the electronic proportional pressure control valve 9 is mounted outside the flow rate control valve.
- variable flow rate control valve 10 may use a variable orifice whose opening area is variably adjusted in proportion to the control signal pressure from the electronic proportional pressure control valve 9.
- a non-explained reference numeral 11 denotes a boom confluence spool that allows the hydraulic fluid of the first hydraulic pump 1 to join the hydraulic fluid of the second hydraulic pump 2 when a boom-up operation is performed.
- the operator manipulates the boom manipulation lever 4 to conduct a boom-up operation and drives the swing device to swivel an upper swing structure in order to perform an excavating and loading work
- the operator manipulates the work mode selection switch 8 to select a certain work mode suitable for various kinds of working conditions such as the height of the ground surface of an excavation work site or the height of a dump vehicle.
- a part of a pilot signal pressure passing by the boom manipulation lever 4 is supplied to a boom spool 5 to shift the boom spool according to the boom-up manipulation of the boom manipulation lever 4.
- the hydraulic fluid discharged from the second hydraulic pump 2 is supplied to a boom cylinder (not shown) after passing through the boom spool 5 to perform the boom-up operation.
- a part of the pilot signal pressure passing by the boom manipulation lever 4 is supplied to the electronic proportional pressure control valve 9 mounted in the pilot flow path 7.
- the electronic proportional pressure control valve 9 outputs a pilot signal pressure in proportion to a select signal corresponding to a work mode selected according to the manipulation of the work mode selection switch 8.
- the signal pressure passing through the electronic proportional pressure control valve 9 is supplied to the variable flow rate control valve 10 so that the opening area of the variable flow rate control valve 10 is controlled. That is, the opening diameter of the variable flow rate control valve 10 is controlled in proportion to the control signal pressure outputted from the electronic proportional pressure control valve 9 depending on the selected work mode.
- the flow rate of the hydraulic fluid discharged from the first hydraulic pump 1 and supplied to the spool 6 for the swing device is reduced to match the selected work mode, and the flow rate of the hydraulic fluid supplied to the boom confluence spool 11 is increased.
- the boom-up operation is performed at a relatively high speed as compared to the swing operation of the upper swing structure so that the loading work can be carried out safely.
- Fig. 3 it can be seen that the hydraulic fluid discharged from the first hydraulic pump 1 is supplied to the boom cylinder in proportion to a pilot signal pressure Pi1 outputted from the electronic proportional pressure control valve 9 to fit the work mode (meaning a line"a"on the graph of Fig. 3 ) selected by the manipulation of the work mode selection switch 8.
- the hydraulic control system for a combined boom and swing operation of a construction machine in accordance with an embodiment of the present invention, it is possible to adjust the driving speeds of the boom and the swing device depending on various kinds of working conditions such as the excavation depth or the height of a dump vehicle during a combined operation in which boom-up and swing manipulations are carried out to perform an excavating and loading work.
- the driving speeds of the boom and the swing device are adjusted under the working conditions needed by the operator, thereby improving convenience and manipulability.
Landscapes
- Engineering & Computer Science (AREA)
- General Engineering & Computer Science (AREA)
- Mining & Mineral Resources (AREA)
- Civil Engineering (AREA)
- Structural Engineering (AREA)
- Physics & Mathematics (AREA)
- Fluid Mechanics (AREA)
- Mechanical Engineering (AREA)
- Operation Control Of Excavators (AREA)
- Fluid-Pressure Circuits (AREA)
Claims (4)
- Ein Hydrauliksteuersystem für einen kombinierten Ausleger- und Schwenkbetrieb einer Baumaschine, das eine erste und zweite Verstell-Hydraulikpumpe (1, 2), eine Betätigungseinrichtung für eine Schwenkvorrichtung und eine Arbeitsvorrichtung, die mit der ersten Hydraulikpumpe (1) verbunden ist, eine Betätigungseinrichtung für eine Arbeitsvorrichtung, die mit der zweiten Hydraulikpumpe (2) verbunden ist, und ein erstes Flussratensteuerventil (3) umfasst, das ausgebildet ist, um eine Flussrate eines Hydraulikfluids zu steuern, das von der ersten und zweiten Hydraulikpumpe (1, 2) jeweils den Betätigungseinrichtungen für die Schwenkvorrichtung und die Arbeitsvorrichtung zugeführt wird, wobei das Hydrauliksteuersystem folgende Merkmale aufweist:einen Arbeitsmodusauswahlschalter (8);ein Proportionaldrucksteuerventil (9), das in einem Pilotfluidweg (7) befestigt ist, das einen Pilotsignaldruck ablässt gemäß einem Bedienbetrag eines Auslegerbedienhebels (4), wenn der Auslegerbedienhebel (4) bedient wird, um einen Ausleger-nach-oben-Betrieb durchzuführen, wobei das Proportionaldrucksteuerventil (9) ausgebildet ist, um einen Steuersignaldruck auszugeben, der proportional zu der Bedienung des Arbeitsmodusauswahlschalters (8) ist;ein zweites Variable-Flussrate-Steuerventil (10), das in einem Flussweg zwischen der ersten Hydraulikpumpe (1) und einem Schwenkvorrichtungssteuerkolben (6) für die Schwenkvorrichtung befestigt ist, wobei das zweite Variable-Flussrate-Steuerventil (10) einen Öffnungsbereich aufweist, der proportional zu dem Steuersignaldruck des Proportionaldrucksteuerventils (9) variabel eingestellt wird;ein Auslegerzusammenflusssteuerkolben (11), undeine Steuerung;gekennzeichnet dadurch, dassdas Proportionaldrucksteuerventil (9) ein elektronisches Proportionaldrucksteuerventil ist,der Arbeitsmodusauswahlschalter (8) ausgebildet ist, um gemäß Arbeitsbedingungen einen Voreinstellungsarbeitsmodus auszuwählen,die Steuerung ausgebildet ist, um gemäß Arbeitsbedingungen verschiedene Arten von Arbeitsmodi einzustellen und zu speichern, um eine Flussrate des Hydraulikfluids zu steuern, das dem Schwenkvorrichtungssteuerkolben (6) und dem Auslegerzusammenflusssteuerkolben (11) zugeführt wird gemäß einem Arbeitsmodus, der ausgewählt wird, wenn der Arbeitsmodusauswahlschalter (8) bedient wird,in dem Fall, in dem eine Bedienperson gemäß den Arbeitsbedingungen während eines kombinierten Betriebs einen bestimmten Arbeitsmodus auswählt, bei dem eine Ausleger-nach-oben- und eine Schwenk-Bedienung ausgeführt werden, wird die Flussrate des Hydraulikfluids, das dem Schwenkvorrichtungssteuerkolben (6) und dem Auslegerzusammenflusssteuerkolben (11) zugeführt wird, gemäß dem ausgewählten Arbeitsmodus variabel gesteuert, um die Antriebsgeschwindigkeiten des Auslegers und der Schwenkvorrichtung einzustellen,ein Teil des Pilotsignaldrucks, der entlang dem Auslegerbedienhebel (4) verläuft, einem Auslegersteuerkolben (5) zugeführt wird, um den Auslegersteuerkolben (5) gemäß der Ausleger-nach-oben-Bedienung des Auslegerbedienhebels (4) zu verschieben, so dass das Hydraulikfluid, das von der zweiten Hydraulikpumpe (2) abgelassen wird, einem Auslegerzylinder zugeführt wird nach dem Verlaufen durch den Auslegersteuerkolben (5), um den Ausleger-nach-oben-Betrieb durchzuführen, undein anderer Teil des Pilotsignaldrucks, der entlang dem Auslegerbedienhebel (4) verläuft, dem elektronischen Proportionaldrucksteuerventil (9) zugeführt wird, das in dem Pilotflussweg (7) befestigt ist.
- Das Hydrauliksteuersystem gemäß Anspruch 1, bei dem das elektronische Proportionaldrucksteuerventil (9) in dem ersten Flussratensteuerventil (3) befestigt ist.
- Das Hydrauliksteuersystem gemäß Anspruch 1, bei dem das elektronische Proportionaldrucksteuerventil (9) außerhalb des ersten Flussratensteuerventils (3) befestigt ist.
- Das Hydrauliksteuersystem gemäß Anspruch 1, bei dem das zweite variable-Flussrate-Steuerventil (10) eine variable Öffnung verwendet, deren Öffnungsbereich proportional zu dem Steuersignaldruck von dem elektronischen Proportionaldrucksteuerventil (9) variabel eingestellt wird.
Applications Claiming Priority (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| PCT/KR2010/009361 WO2012091187A1 (ko) | 2010-12-27 | 2010-12-27 | 건설기계의 붐-선회 복합구동 유압 제어시스템 |
Publications (3)
| Publication Number | Publication Date |
|---|---|
| EP2660478A1 EP2660478A1 (de) | 2013-11-06 |
| EP2660478A4 EP2660478A4 (de) | 2014-08-20 |
| EP2660478B1 true EP2660478B1 (de) | 2017-03-15 |
Family
ID=46383250
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| EP10861359.7A Not-in-force EP2660478B1 (de) | 2010-12-27 | 2010-12-27 | Hydraulisches steuersystem eines auslegerdrehgelenkverbundantriebs einer einer baumaschine |
Country Status (6)
| Country | Link |
|---|---|
| US (1) | US20130291530A1 (de) |
| EP (1) | EP2660478B1 (de) |
| JP (1) | JP2014505810A (de) |
| KR (1) | KR20130137192A (de) |
| CN (1) | CN103299089B (de) |
| WO (1) | WO2012091187A1 (de) |
Families Citing this family (13)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CA2880618C (en) * | 2012-08-27 | 2016-10-11 | Volvo Construction Equipment Ab | Hydraulic system for construction machinery |
| US9926135B2 (en) * | 2012-10-09 | 2018-03-27 | The Heil Co. | Externally controlled switch mechanism |
| CN103015473A (zh) * | 2012-12-10 | 2013-04-03 | 三一重机有限公司 | 挖掘机、动臂对回转优先控制方法及优先阀 |
| JP6220228B2 (ja) * | 2013-10-31 | 2017-10-25 | 川崎重工業株式会社 | 建設機械の油圧駆動システム |
| KR102131447B1 (ko) | 2013-11-12 | 2020-07-08 | 현대모비스 주식회사 | 차량의 에어벤트 |
| CN107429716B (zh) * | 2015-01-08 | 2019-05-14 | 沃尔沃建筑设备公司 | 建筑机械的液压致动器的驱动控制方法 |
| EP3428350B1 (de) * | 2016-03-11 | 2021-03-03 | Hitachi Construction Machinery Co., Ltd. | Steuerungsvorrichtung für baumaschinen |
| CN109563696B (zh) * | 2017-05-09 | 2021-05-07 | 日立建机株式会社 | 作业机械 |
| US11286962B2 (en) * | 2017-09-29 | 2022-03-29 | Volvo Construction Equipment Ab | Flow control valve and hydraulic machine including the same |
| CA3081344C (en) * | 2017-11-01 | 2023-10-17 | Clark Equipment Company | Control system for power machine |
| DE102019201182A1 (de) * | 2019-01-30 | 2020-07-30 | Putzmeister Engineering Gmbh | Fahrzeug |
| EP3943674B1 (de) * | 2019-03-19 | 2025-08-20 | Sumitomo Construction Machinery Co., Ltd. | Bagger |
| EP4335981B1 (de) * | 2022-09-08 | 2024-10-30 | XCMG European Research Center GmbH | Baumaschine mit einem hydrauliksystem |
Family Cites Families (14)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| KR920010874B1 (ko) * | 1988-03-03 | 1992-12-19 | 히다찌 겐끼 가부시기가이샤 | 유압기계의 유압구동방법 및 유압구동장치 |
| DE69029633T2 (de) * | 1989-03-22 | 1997-05-07 | Hitachi Construction Machinery | Hydraulisches antriebssystem für das bauwesen und für baumaschinen |
| US5125232A (en) * | 1990-05-29 | 1992-06-30 | Kubota Corporation | Control change system for a hydraulic working vehicle |
| JP2583148B2 (ja) * | 1990-06-19 | 1997-02-19 | 株式会社小松製作所 | 油圧式掘削機の油圧制御回路 |
| KR960013596B1 (ko) * | 1992-07-29 | 1996-10-09 | 현대중장비산업 주식회사 | 건설기계의 작업 자동제어 장치 |
| JP3078947B2 (ja) * | 1993-03-30 | 2000-08-21 | 株式会社神戸製鋼所 | 流体圧アクチュエータの駆動制御装置 |
| JP3477687B2 (ja) * | 1993-11-08 | 2003-12-10 | 日立建機株式会社 | 流量制御装置 |
| KR0162960B1 (ko) * | 1995-06-23 | 1999-01-15 | 석진철 | 굴삭기의 조작성 향상 유량제어장치 |
| US6050090A (en) * | 1996-06-11 | 2000-04-18 | Kabushiki Kaisha Kobe Seiko Sho | Control apparatus for hydraulic excavator |
| JPH10220411A (ja) * | 1997-02-06 | 1998-08-21 | Hitachi Constr Mach Co Ltd | 油圧パイロット操作装置 |
| JP4475767B2 (ja) * | 2000-08-03 | 2010-06-09 | 株式会社小松製作所 | 作業用車両 |
| US20050139273A1 (en) * | 2003-12-29 | 2005-06-30 | Tecnord S.R.L. | Electromechanically controlled proportional valve |
| KR101144396B1 (ko) * | 2004-12-16 | 2012-05-11 | 두산인프라코어 주식회사 | 굴삭기의 선회복합작업용 유압제어장치 |
| KR100900436B1 (ko) * | 2007-05-21 | 2009-06-01 | 볼보 컨스트럭션 이키프먼트 홀딩 스웨덴 에이비 | 무한궤도형 중장비의 주행장치 |
-
2010
- 2010-12-27 CN CN201080071033.5A patent/CN103299089B/zh not_active Expired - Fee Related
- 2010-12-27 EP EP10861359.7A patent/EP2660478B1/de not_active Not-in-force
- 2010-12-27 JP JP2013547272A patent/JP2014505810A/ja active Pending
- 2010-12-27 KR KR1020137016543A patent/KR20130137192A/ko not_active Ceased
- 2010-12-27 US US13/996,818 patent/US20130291530A1/en not_active Abandoned
- 2010-12-27 WO PCT/KR2010/009361 patent/WO2012091187A1/ko not_active Ceased
Non-Patent Citations (1)
| Title |
|---|
| None * |
Also Published As
| Publication number | Publication date |
|---|---|
| WO2012091187A1 (ko) | 2012-07-05 |
| US20130291530A1 (en) | 2013-11-07 |
| EP2660478A4 (de) | 2014-08-20 |
| EP2660478A1 (de) | 2013-11-06 |
| CN103299089A (zh) | 2013-09-11 |
| JP2014505810A (ja) | 2014-03-06 |
| CN103299089B (zh) | 2016-08-10 |
| KR20130137192A (ko) | 2013-12-16 |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| CN101107400B (zh) | 建筑机械的控制模式切换装置以及建筑机械 | |
| KR100807923B1 (ko) | 작업용 차량의 속도제어장치 및 그의 속도제어방법 | |
| EP1995155B1 (de) | Antriebsvorrichtung für Raupen-Baumaschinen | |
| EP2660478A1 (de) | Hydraulisches steuersystem eines auslegerdrehgelenkverbundantriebs einer einer baumaschine | |
| CN109563696B (zh) | 作业机械 | |
| KR102159596B1 (ko) | 건설 기계 | |
| CN102741483B (zh) | 液压作业机 | |
| EP3647500B1 (de) | Fahrsteuersystem für baumaschinen und fahrsteuerverfahren für baumaschinen | |
| US9074346B2 (en) | Work machine and control method for work machines | |
| EP3505688B1 (de) | System zur steuerung einer baumaschine und verfahren zur steuerung einer baumaschine | |
| US9057175B2 (en) | Construction machine with hydraulic circuit | |
| EP3604823B1 (de) | Baumaschine | |
| KR20150086251A (ko) | 건설기계의 선회 제어장치 및 그 제어방법 | |
| JP2018135704A (ja) | 油圧ショベル | |
| KR20100044585A (ko) | 선회장치를 구비하는 건설장비용 유압회로 | |
| US10934686B2 (en) | Working machine | |
| US11078645B2 (en) | Slewing-type working machine | |
| US20250188710A1 (en) | Hydraulic drive apparatus | |
| US11408145B2 (en) | Work vehicle and hydraulic control method | |
| JPH11324026A (ja) | 建設機械における操作子とアクチュエータ組合せ変更装置および作業モード変更装置 | |
| JP2002317471A (ja) | 油圧ショベルの油圧制御回路 | |
| JPH11229444A (ja) | 建設機械の油圧制御装置およびその油圧制御方法 | |
| JP2026073540A (ja) | 作業機械 | |
| JPH09165791A (ja) | 作業機械の油圧回路 | |
| KR20260014665A (ko) | 작업 기계 |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| PUAI | Public reference made under article 153(3) epc to a published international application that has entered the european phase |
Free format text: ORIGINAL CODE: 0009012 |
|
| 17P | Request for examination filed |
Effective date: 20130625 |
|
| AK | Designated contracting states |
Kind code of ref document: A1 Designated state(s): AL AT BE BG CH CY CZ DE DK EE ES FI FR GB GR HR HU IE IS IT LI LT LU LV MC MK MT NL NO PL PT RO RS SE SI SK SM TR |
|
| DAX | Request for extension of the european patent (deleted) | ||
| A4 | Supplementary search report drawn up and despatched |
Effective date: 20140722 |
|
| RIC1 | Information provided on ipc code assigned before grant |
Ipc: F15B 13/044 20060101ALI20140716BHEP Ipc: F15B 11/17 20060101ALI20140716BHEP Ipc: F15B 13/02 20060101AFI20140716BHEP Ipc: E02F 9/20 20060101ALI20140716BHEP Ipc: E02F 9/22 20060101ALI20140716BHEP |
|
| 17Q | First examination report despatched |
Effective date: 20150629 |
|
| GRAP | Despatch of communication of intention to grant a patent |
Free format text: ORIGINAL CODE: EPIDOSNIGR1 |
|
| INTG | Intention to grant announced |
Effective date: 20160922 |
|
| GRAS | Grant fee paid |
Free format text: ORIGINAL CODE: EPIDOSNIGR3 |
|
| GRAA | (expected) grant |
Free format text: ORIGINAL CODE: 0009210 |
|
| AK | Designated contracting states |
Kind code of ref document: B1 Designated state(s): AL AT BE BG CH CY CZ DE DK EE ES FI FR GB GR HR HU IE IS IT LI LT LU LV MC MK MT NL NO PL PT RO RS SE SI SK SM TR |
|
| REG | Reference to a national code |
Ref country code: CH Ref legal event code: EP Ref country code: GB Ref legal event code: FG4D |
|
| REG | Reference to a national code |
Ref country code: IE Ref legal event code: FG4D |
|
| REG | Reference to a national code |
Ref country code: AT Ref legal event code: REF Ref document number: 875890 Country of ref document: AT Kind code of ref document: T Effective date: 20170415 |
|
| REG | Reference to a national code |
Ref country code: DE Ref legal event code: R096 Ref document number: 602010040870 Country of ref document: DE |
|
| REG | Reference to a national code |
Ref country code: NL Ref legal event code: MP Effective date: 20170315 |
|
| REG | Reference to a national code |
Ref country code: LT Ref legal event code: MG4D |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: HR Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20170315 Ref country code: NO Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20170615 Ref country code: GR Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20170616 Ref country code: FI Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20170315 Ref country code: LT Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20170315 |
|
| REG | Reference to a national code |
Ref country code: AT Ref legal event code: MK05 Ref document number: 875890 Country of ref document: AT Kind code of ref document: T Effective date: 20170315 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: SE Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20170315 Ref country code: BG Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20170615 Ref country code: LV Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20170315 Ref country code: RS Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20170315 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: NL Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20170315 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: RO Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20170315 Ref country code: SK Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20170315 Ref country code: ES Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20170315 Ref country code: CZ Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20170315 Ref country code: AT Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20170315 Ref country code: EE Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20170315 Ref country code: IT Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20170315 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: PL Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20170315 Ref country code: PT Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20170717 Ref country code: SM Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20170315 Ref country code: IS Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20170715 |
|
| REG | Reference to a national code |
Ref country code: DE Ref legal event code: R097 Ref document number: 602010040870 Country of ref document: DE |
|
| PLBE | No opposition filed within time limit |
Free format text: ORIGINAL CODE: 0009261 |
|
| STAA | Information on the status of an ep patent application or granted ep patent |
Free format text: STATUS: NO OPPOSITION FILED WITHIN TIME LIMIT |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: DK Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20170315 |
|
| 26N | No opposition filed |
Effective date: 20171218 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: SI Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20170315 |
|
| REG | Reference to a national code |
Ref country code: DE Ref legal event code: R119 Ref document number: 602010040870 Country of ref document: DE |
|
| REG | Reference to a national code |
Ref country code: CH Ref legal event code: PL |
|
| GBPC | Gb: european patent ceased through non-payment of renewal fee |
Effective date: 20171227 |
|
| REG | Reference to a national code |
Ref country code: IE Ref legal event code: MM4A |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: MT Free format text: LAPSE BECAUSE OF NON-PAYMENT OF DUE FEES Effective date: 20171227 Ref country code: LU Free format text: LAPSE BECAUSE OF NON-PAYMENT OF DUE FEES Effective date: 20171227 |
|
| REG | Reference to a national code |
Ref country code: FR Ref legal event code: ST Effective date: 20180831 |
|
| REG | Reference to a national code |
Ref country code: BE Ref legal event code: MM Effective date: 20171231 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: FR Free format text: LAPSE BECAUSE OF NON-PAYMENT OF DUE FEES Effective date: 20180102 Ref country code: IE Free format text: LAPSE BECAUSE OF NON-PAYMENT OF DUE FEES Effective date: 20171227 Ref country code: DE Free format text: LAPSE BECAUSE OF NON-PAYMENT OF DUE FEES Effective date: 20180703 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: CH Free format text: LAPSE BECAUSE OF NON-PAYMENT OF DUE FEES Effective date: 20171231 Ref country code: BE Free format text: LAPSE BECAUSE OF NON-PAYMENT OF DUE FEES Effective date: 20171231 Ref country code: LI Free format text: LAPSE BECAUSE OF NON-PAYMENT OF DUE FEES Effective date: 20171231 Ref country code: GB Free format text: LAPSE BECAUSE OF NON-PAYMENT OF DUE FEES Effective date: 20171227 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: HU Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT; INVALID AB INITIO Effective date: 20101227 Ref country code: MC Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20170315 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: CY Free format text: LAPSE BECAUSE OF NON-PAYMENT OF DUE FEES Effective date: 20170315 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: MK Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20170315 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: TR Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20170315 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: AL Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20170315 |