EP4342631A1 - Procédé de mise en forme d'un produit ophtalmique - Google Patents
Procédé de mise en forme d'un produit ophtalmique Download PDFInfo
- Publication number
- EP4342631A1 EP4342631A1 EP22306407.2A EP22306407A EP4342631A1 EP 4342631 A1 EP4342631 A1 EP 4342631A1 EP 22306407 A EP22306407 A EP 22306407A EP 4342631 A1 EP4342631 A1 EP 4342631A1
- Authority
- EP
- European Patent Office
- Prior art keywords
- machining
- ophthalmic product
- shaping according
- lens
- ophthalmic
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Pending
Links
Images
Classifications
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B24—GRINDING; POLISHING
- B24B—MACHINES, DEVICES, OR PROCESSES FOR GRINDING OR POLISHING; DRESSING OR CONDITIONING OF ABRADING SURFACES; FEEDING OF GRINDING, POLISHING, OR LAPPING AGENTS
- B24B51/00—Arrangements for automatic control of a series of individual steps in grinding a workpiece
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B24—GRINDING; POLISHING
- B24B—MACHINES, DEVICES, OR PROCESSES FOR GRINDING OR POLISHING; DRESSING OR CONDITIONING OF ABRADING SURFACES; FEEDING OF GRINDING, POLISHING, OR LAPPING AGENTS
- B24B49/00—Measuring or gauging equipment for controlling the feed movement of the grinding tool or work; Arrangements of indicating or measuring equipment, e.g. for indicating the start of the grinding operation
- B24B49/006—Measuring or gauging equipment for controlling the feed movement of the grinding tool or work; Arrangements of indicating or measuring equipment, e.g. for indicating the start of the grinding operation taking regard of the speed
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B24—GRINDING; POLISHING
- B24B—MACHINES, DEVICES, OR PROCESSES FOR GRINDING OR POLISHING; DRESSING OR CONDITIONING OF ABRADING SURFACES; FEEDING OF GRINDING, POLISHING, OR LAPPING AGENTS
- B24B49/00—Measuring or gauging equipment for controlling the feed movement of the grinding tool or work; Arrangements of indicating or measuring equipment, e.g. for indicating the start of the grinding operation
- B24B49/02—Measuring or gauging equipment for controlling the feed movement of the grinding tool or work; Arrangements of indicating or measuring equipment, e.g. for indicating the start of the grinding operation according to the instantaneous size and required size of the workpiece acted upon, the measuring or gauging being continuous or intermittent
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B24—GRINDING; POLISHING
- B24B—MACHINES, DEVICES, OR PROCESSES FOR GRINDING OR POLISHING; DRESSING OR CONDITIONING OF ABRADING SURFACES; FEEDING OF GRINDING, POLISHING, OR LAPPING AGENTS
- B24B49/00—Measuring or gauging equipment for controlling the feed movement of the grinding tool or work; Arrangements of indicating or measuring equipment, e.g. for indicating the start of the grinding operation
- B24B49/16—Measuring or gauging equipment for controlling the feed movement of the grinding tool or work; Arrangements of indicating or measuring equipment, e.g. for indicating the start of the grinding operation taking regard of the load
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B24—GRINDING; POLISHING
- B24B—MACHINES, DEVICES, OR PROCESSES FOR GRINDING OR POLISHING; DRESSING OR CONDITIONING OF ABRADING SURFACES; FEEDING OF GRINDING, POLISHING, OR LAPPING AGENTS
- B24B9/00—Machines or devices designed for grinding edges or bevels on work or for removing burrs; Accessories therefor
- B24B9/02—Machines or devices designed for grinding edges or bevels on work or for removing burrs; Accessories therefor characterised by a special design with respect to properties of materials specific to articles to be ground
- B24B9/06—Machines or devices designed for grinding edges or bevels on work or for removing burrs; Accessories therefor characterised by a special design with respect to properties of materials specific to articles to be ground of non-metallic inorganic material, e.g. stone, ceramics, porcelain
- B24B9/08—Machines or devices designed for grinding edges or bevels on work or for removing burrs; Accessories therefor characterised by a special design with respect to properties of materials specific to articles to be ground of non-metallic inorganic material, e.g. stone, ceramics, porcelain of glass
- B24B9/14—Machines or devices designed for grinding edges or bevels on work or for removing burrs; Accessories therefor characterised by a special design with respect to properties of materials specific to articles to be ground of non-metallic inorganic material, e.g. stone, ceramics, porcelain of glass of optical work, e.g. lenses, prisms
Definitions
- the present invention generally relates to the field of eyeglasses.
- This invention applies to machining devices comprising:
- the invention more particularly relates to a process for shaping an ophthalmic lens, comprising:
- the technical part of the work of an optician which consists in mounting a pair of ophthalmic lenses in a spectacle frame selected by a customer, may be split into four main operations:
- the edging operation is more particularly of interest.
- This operation is generally carried out by an edging machine, as a function of the material of the lens to be edged.
- the machining method aims at maintaining constant the machining speed, that is to say the speed of the contact point between the lens and the tool.
- the control parameters are consequently calculated before machining the lens, considering the material of the lens to be edged.
- the machining depth is calculated according to the average power consumed by the motor at the previous turn, in order to reduce the time needed to edge the lens.
- the present invention provides a solution enabling to use the edging machine to its maximum capacity in order to optimize productivity.
- the invention is directed to a process for shaping an ophthalmic product as defined in the introduction wherein, during the step of roughing out, the value of said force is measured by the force sensor, and the machining speed is continuously adjusted so as to maintain the measured value equal to a target value.
- the tool is driven so as to machine the ophthalmic product at the maximum possible speed.
- the target value is maintained at a level that is high in order to shorten the machining time, and that is such that the motor consumption does not exceed a maximum value that would harm the quality of the product.
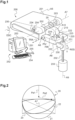
- Figure 1 shows a device 200 for machining an ophthalmic lens 20, comprising:
- This machining device 200 could take the form of any machine for cutting or removing material, able to modify the outline of the ophthalmic lens 20 in order to adapt it to that of the corresponding eyewire of a spectacle frame selected by an individual.
- the machining device 200 consists, as is known per se, of an automatic grinder 200, widely referred to as a digital grinder.
- this grinder comprises:
- the pivoting mobility of the rocker 201 about the reference axis is called retraction mobility ESC. It allows the ophthalmic lens 20 to be brought closer to the abrasive wheel 210 until the former makes contact with the latter.
- This rocker 201 is equipped with two shafts 202, 203 for clamping the ophthalmic lens 20 to be machined and for driving it to rotate, which shafts 202, 203 correspond to the aforementioned "clamping means".
- Each of the shafts 202, 203 possesses a free end that faces the other and that is equipped with a head for clamping the ophthalmic lens 20.
- a first 202 of the two shafts is fixed in translation along the clamping axis A7.
- the second 203 of the two shafts is mobile in translation along the blocking axis A7 in order to allow the ophthalmic lens 20 to be compressively clamped axially between the two clamping heads.
- the grinder 200 schematically shown in figure 1 comprises only one cylinder abrasive wheel 210.
- each abrasive wheel being used for a specific shaping operation of the ophthalmic lens 20 to be machined.
- a roughing-out cylinder abrasive wheel is used for the roughing-out of the lens.
- This roughing-out cylinder abrasive wheel is cylindrical, it has a diameter greater than 10 centimetres, and it comprises diamonds whose grain size is between 100 and 500 micrometers and is here equal to 300 micrometers.
- a shaping abrasive wheel (or “beveling abrasive wheel”) can be used, this abrasive wheel containing a beveling groove of dihedral cross-section.
- a cylinder abrasive wheel and a shaping abrasive wheel are used, the grain sizes of these polishing abrasive wheels being particularly small.
- the set of abrasive wheels is born by a slide (not shown) so as to move in translation along the abrasive-wheel axis A6.
- the translational movement of the slide bearing the abrasive wheels is called the "transfer" TRA.
- the grinder 200 furthermore comprises a link rod 230 one end of which is hinged relative to the mounting in order to pivot about the reference axis A5, and the other end of which is hinged relative to a nut 231 in order to pivot about an axis A8 parallel to the reference axis A5.
- the nut 231 is itself mounted to move in translation along a restitution axis A9 perpendicular to the reference axis A5.
- the nut 231 is a tapped nut in screwed engagement with a threaded shank 232 that, aligned with the restitution axis A9, is driven to rotate by a motor 233.
- the link rod 230 moreover comprises a force sensor 234, here consisting of a unidirectional strain gauge, that interacts with a stop 204 fixed to the rocker 201.
- the ophthalmic lens 20 to be machined When, duly clamped between the two shafts 202, 203, the ophthalmic lens 20 to be machined is brought into contact with one of the abrasive wheels 210, it is the object of an effective removal of material until the stop 204 of the rocker 201 buts against the link rod 230 with a force that, acting on the strain gauge 234, is duly detected and measured by the latter.
- the strain gauge 234 is placed so as to measure a machining force of substantially vertical direction, corresponding to the radial component of the force exerted by the ophthalmic lens 20 on the abrasive wheel 210 or finishing tool 222, 223 used.
- the retraction movement is in particular controlled depending on the machining force measured by the strain gauge 234, so as to maintain it equal to a target value.
- the non-essential finishing module 220 has a pivoting mobility about the abrasive-wheel axis A6, which mobility is denoted PIV. This mobility allows it to be brought closer to or moved further away from the ophthalmic lens 20.
- finishing tools 222, 223 with which the finishing module 220 is equipped here especially comprise a grooving disk 222 adapted to produce a groove along the edge face of the ophthalmic lens 20, and a milling cutter 223 adapted to chamfer the sharp edges of the ophthalmic lens 20.
- finishing tools 222, 223 are mounted to rotate about a given axis and are driven to rotate by a motor housed in a base 224 that is itself mounted to pivot on the finishing module 220 about an axis A10 orthogonal to the abrasive-wheel axis A6.
- This pivoting mobility of the base 224 about the axis A10 called the finishing mobility FIN, allows the tools 222, 223 to be best oriented relative to the lens.
- the controlling unit 251 is an electronic and/or computing unit and it in particular allows the following to be controlled:
- the grinder 200 comprises a human-machine interface 252 that here comprises a display screen 253, a keyboard 254 and a mouse 255, which are adapted to communicate with the controlling unit 251.
- This HMI interface 252 allows the user to enter numerical values, such as the material of the lens, on the display screen 253, so that the tools of the grinder 200 can be appropriately controlled.
- the controlling unit is implemented on a desktop computer connected to the grinder 200.
- the software portion of the grinder could be implemented directly on an electronic circuit of the grinder. It could also be implemented on a remote computer, communicating with the grinder via a private or public network, for example using an IP (Internet) communication protocol.
- IP Internet
- Figure 2 shows a projection of the initial outline 21 of the lens 20 to be machined.
- This final outline 22 corresponds to the bottom of a bezel of a rim of the spectacle frame selected by the individual that is suitable to receive the lens once machined.
- Figure 2 also shows a "boxing system" of this final outline 22.
- this boxing system comprises a box 23 that is a rectangle drawn around the projection of the final outline 22, which has two horizontal sides.
- the centre O of this box 23 is called boxing center.
- the lens is to be blocked between the two shafts 202, 203 such that the blocking axis A7 passes through this boxing center.
- the controlling unit 251 acquires the geometry of the final outline 22.
- this final outline 22 takes the form of a set of triplets (r i , ⁇ i , z i ) corresponding to the cylindrical coordinates of a plurality of points P i characterizing the shape of this final outline 22.
- These coordinates can be acquired from a database to which an optician has access, or by using an imaging device comprising image-capturing means and image-processing means suitable to process a photo of a sample lens delivered with the spectacle frame, or by feeling the bottom of the bezel of the rim of the frame selected by the individual.
- the lens is then subjected to a centering operation followed by a blocking operation.
- the positions of markers marked or etched on the lens are determined, and the position required for the final outline 22 is deduced therefrom (so that once the lens has been shaped following this outline and fitted into the selected frame, its optical centre is correctly located relative to the corresponding eye of the spectacle wearer).
- a gripping accessory is adhesively bonded to the lens in a position centered on the boxing centre, then, by virtue of this gripping accessory, the lens is clamped between the shafts 202, 203 of the edger 200 such that the boxing centre is located centered on the clamping axis A7.
- the shaping is then carried out in two operations, namely a roughing-out operation and a finishing operation.
- the roughing-out cylinder abrasive wheel 210 is used to coarsely decrease the radii of the lens 20 to the shape of the final outline 22. More precisely, the shafts 202, 203 and the rocker 201 are here controlled relative to each other so as to decrease, for each angular position ⁇ i of the lens about the clamping axis A7, the radius of the lens to a length equal to the radius r i of the final outline 20.
- the shaping abrasive wheel and/or any other finishing tool is used to form, on the edge face of the lens, a "bevel" or a groove or any suitable form, and to polish the obtained edge.
- the invention is more particularly directed to the step of roughing-out.
- the abrasive wheel 210 follows, relative to the lens 20, a first path Pa1 that is radiale relative to the axis A7 until its peripheral edge reaches the final outline 22. Then, it follows a second path Pa2 along the final outline 22 (see Fig.2 ).
- the lens 20 is machined in a single pass around the axis A7.
- the roughing-out step is performed so as to reduce the time required to machine the edge of the lens 20.
- machining speed MSp also called “machining rate”
- This machining speed could be defined as being the rotation speed of the shafts 202, 203.
- the machining speed is defined as the speed of the point of contact between the lens 20 and the abrasive wheel 210.
- this machining speed MSp depends on the rotation speed of the shafts 202, 203 and on the radius of the contact point relative to axis A7.
- the grinder 200 is designed so that the machining speed MSp can reach a known "maximum machining speed" or a known shaft rotation speed.
- the grinding machine 200 is designed such that it can reach a known “maximum shaft rotation speed” or so that the machining speed MSp can reach a known “maximum machining speed”.
- the process for roughing-out the lens 20 is performed in loops so that the machining of the lens edge progresses at each loop point by point along the final outline 22.
- sampling interval ⁇ t the time between two successive loops.
- the idea of the invention is to discretise the final outline 22 into several main points and to search in real time for the next point to be reached at the end of each instant sampling interval ⁇ t.
- the first main point P 0 can be selected randomly.
- the number N of main points P i (with i lying from 0 to N-1) is determined as a function of said maximum machining speed and/or of said maximum shaft rotation speed.
- the maximum shaft rotation speed is considered.
- the latter is regarded as being equal to 10 rpm when the sampling interval ⁇ t is settled to 1 ms.
- the final outline 22 is initially characterized by 6000 main points P i the coordinates (r i , ⁇ i , z i ) of which are defined.
- intermediate points P 0j are added in real time during the roughing-out step and they are defined only by one of their coordinates: their orientation ⁇ j .
- the use of intermediate points P 0j rather than a greater number N of main points P i enables not to have to determine a great number of triplets (r i , ⁇ i , z i ).
- sampling The method used to add these intermediate points P 0j is named sampling. In practice, it consists in adding, at each loop and only if it is necessary, a predefined number n of intermediate points P 0j between the two next main points P i .
- these intermediate points P 0j are added between the main points P 0 and P 1 .
- the predefined number n of added intermediate points P 0j is at least equal to 10, and is here equal to 100.
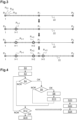
- next point P t+1 to be reached at the next sampling instant t+1 is selected between these intermediate points P 0j and the second main point P 1 , so as to maintain the measured value F meas equal to a target value F targ (see the second drawing of Figure 3 ).
- the first parameter is the target value F targ of the measured force
- the second parameter is the machining speed Msp.
- the method for adjusting the target value F targ according to the intrinsic characteristics of the material of the lens (kind of material, amount of material to machine%) and to the operating conditions of the machine (electrical voltage, state of maintenance%) is shown in the left part of Figure 4 . It comprises several steps.
- these steps are performed in loops, but these loops can be desynchronized from the above-mentioned loops.
- the sampling interval of these desynchronized loops can be distinct from said sampling interval ⁇ t and can vary from one loop to another.
- the first step S0 shown in Figure 4 represents the beginning of the roughing-out step.
- the second step S2 consists in determining an initial target value F targ .
- this initial target value depends only from the operating conditions of the grinder 200, and more specifically from its nominal power.
- step S4 the determined target value F targ is compared with a predetermined threshold F up .
- This predetermined threshold F up depends on the used grinder 200. It is for instance equal to 2500g. It corresponds to a minimum value of the force below which it is considered that no problem can arise.
- step S12 (described hereinafter) is implemented.
- step S6 the instant electrical power P el consumed by the grinder 200 is acquired and compared with a power threshold P max .
- This power threshold P max depends on the used grinder. It is for instance equal to 900W. It corresponds to a power equal or next from the maximum power the grinder can consume.
- step S12 is implemented.
- the target value F targ is reduced of a predetermined amount. This amount is for instance equal to 500g.
- step S10 a temporisation is triggered, then step S12 is implemented.
- This temporisation is for instance of 0.8s.
- Step S12 consists in determining whether the roughing-out step is finished or not.
- step S14 If it is finished, the process ends (step S14). Else, the process is restarted at step S4.
- the target value F targ is adjusted as a function of the grinder possibilities.
- a new machining speed Msp is determined at each loop defined by the sampling interval ⁇ t.
- the process for adjusting the machining speed MSp according to the target value F targ and to the measured value F meas is implemented in parallel of the determination of said target value.
- This process is based on a proportional derivative controller and comprises the following steps.
- the processing unit 251 determines a first difference between the measured value F meas and the target value F targ , named force error ⁇ F.
- the processing unit 251 calculates the machining speed MSp according to the force error ⁇ F and the derivative ⁇ F.
- the processing unit is able to determine the next point P t+1 to be reached at the end of the sampling interval ⁇ t.
- the processing units determines its coordinates (r j , ⁇ j , z j ). Indeed, only the orientations ⁇ j of the intermediate points P 0j are known.
- the other coordinates can be determined by interpolation, on the basis of at least the orientation ⁇ j and the coordinates (r i , ⁇ i , z i ) and (r i+1 , ⁇ i+1 , z i+1 ) of the two main points located on either side of the next point P t+1 .
- the process can apply to the machining of other ophthalmic products, for instance to the machining of molds suitable for molding ophthalmic lenses.
Landscapes
- Engineering & Computer Science (AREA)
- Mechanical Engineering (AREA)
- Chemical & Material Sciences (AREA)
- Ceramic Engineering (AREA)
- Inorganic Chemistry (AREA)
- Grinding And Polishing Of Tertiary Curved Surfaces And Surfaces With Complex Shapes (AREA)
Priority Applications (4)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| EP22306407.2A EP4342631A1 (fr) | 2022-09-23 | 2022-09-23 | Procédé de mise en forme d'un produit ophtalmique |
| CN202380060638.1A CN119768252A (zh) | 2022-09-23 | 2023-09-21 | 用于使眼科产品成形的方法 |
| US19/101,806 US20260048478A1 (en) | 2022-09-23 | 2023-09-21 | Process for shaping an ophthalmic product |
| PCT/EP2023/076137 WO2024062064A1 (fr) | 2022-09-23 | 2023-09-21 | Processus pour façonner un produit ophtalmique |
Applications Claiming Priority (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| EP22306407.2A EP4342631A1 (fr) | 2022-09-23 | 2022-09-23 | Procédé de mise en forme d'un produit ophtalmique |
Publications (1)
| Publication Number | Publication Date |
|---|---|
| EP4342631A1 true EP4342631A1 (fr) | 2024-03-27 |
Family
ID=83689640
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| EP22306407.2A Pending EP4342631A1 (fr) | 2022-09-23 | 2022-09-23 | Procédé de mise en forme d'un produit ophtalmique |
Country Status (4)
| Country | Link |
|---|---|
| US (1) | US20260048478A1 (fr) |
| EP (1) | EP4342631A1 (fr) |
| CN (1) | CN119768252A (fr) |
| WO (1) | WO2024062064A1 (fr) |
Citations (1)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| EP2623261A2 (fr) * | 2012-02-03 | 2013-08-07 | Nidek Co., Ltd | Appareil de traitement des lentilles ophtalmiques |
-
2022
- 2022-09-23 EP EP22306407.2A patent/EP4342631A1/fr active Pending
-
2023
- 2023-09-21 WO PCT/EP2023/076137 patent/WO2024062064A1/fr not_active Ceased
- 2023-09-21 CN CN202380060638.1A patent/CN119768252A/zh active Pending
- 2023-09-21 US US19/101,806 patent/US20260048478A1/en active Pending
Patent Citations (1)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| EP2623261A2 (fr) * | 2012-02-03 | 2013-08-07 | Nidek Co., Ltd | Appareil de traitement des lentilles ophtalmiques |
Also Published As
| Publication number | Publication date |
|---|---|
| CN119768252A (zh) | 2025-04-04 |
| US20260048478A1 (en) | 2026-02-19 |
| WO2024062064A1 (fr) | 2024-03-28 |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| US5148637A (en) | Lens edging system with programmable feed and speed control | |
| EP0444902B1 (fr) | Système d'usinage des bords de lentille | |
| US8931899B2 (en) | Method for trimming an opthalmic lens | |
| US8556419B2 (en) | Method of preparing an ophthalmic lens with special machining of its engagement ridge | |
| US7643899B2 (en) | Method of beveling an ophthalmic lens blank, machine programmed therefor, and computer program | |
| EP3542958B1 (fr) | Procédé et machine de préparation d'une lentille ophtalmique à ébavurer | |
| US20260048478A1 (en) | Process for shaping an ophthalmic product | |
| US10357865B2 (en) | Method for bevelling an ophthalmic lens | |
| JP3602303B2 (ja) | 眼鏡レンズ研削加工装置 | |
| JP3854057B2 (ja) | 眼鏡レンズの光学中心測定方法並びに眼鏡レンズのレンズホルダ取付方法及び装置 | |
| EP4431232A1 (fr) | Procédé de façonnage d'une lentille optique | |
| US8845390B2 (en) | Predictive calculation method for calculating a simulated shape of an engagement ridge to be arranged on the edge face of an ophthalmic lens of a pair of eyeglasses, and a method of beveling | |
| WO2025249140A1 (fr) | Dispositif de traitement de verres de lunettes et programme de commande pour dispositif de traitement de verres de lunettes | |
| EP4382249A1 (fr) | Procédé de génération d'une consigne d'usinage pour chanfreiner une lentille ophtalmique | |
| JP2002254387A (ja) | 眼鏡用プラスチックレンズの加工方法およびその装置 | |
| US8672479B2 (en) | Visual device including an ophthalmic lens having a partially cropped insertion rib, and method for preparing such lens | |
| KR20150011923A (ko) | 안경 렌즈의 자동 가공 방법 | |
| JP3300218B2 (ja) | 眼鏡レンズの縁摺り加工方法および縁摺り加工装置 | |
| JP2003300138A (ja) | レンズ加工方法及びレンズ加工装置並びに眼鏡レンズ | |
| JP2019063939A (ja) | 眼鏡レンズ加工装置及び眼鏡レンズ加工プログラム | |
| JP2002196289A (ja) | 眼鏡レンズ加工方法及び装置 | |
| JPH04372352A (ja) | 玉摺機 | |
| MXPA96003307A (es) | Procedimiento y herramienta para la produccion deuna superficie concava a partir de una pieza decristal de anteojos |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| PUAI | Public reference made under article 153(3) epc to a published international application that has entered the european phase |
Free format text: ORIGINAL CODE: 0009012 |
|
| STAA | Information on the status of an ep patent application or granted ep patent |
Free format text: STATUS: THE APPLICATION HAS BEEN PUBLISHED |
|
| AK | Designated contracting states |
Kind code of ref document: A1 Designated state(s): AL AT BE BG CH CY CZ DE DK EE ES FI FR GB GR HR HU IE IS IT LI LT LU LV MC MK MT NL NO PL PT RO RS SE SI SK SM TR |
|
| STAA | Information on the status of an ep patent application or granted ep patent |
Free format text: STATUS: REQUEST FOR EXAMINATION WAS MADE |
|
| 17P | Request for examination filed |
Effective date: 20240823 |
|
| RBV | Designated contracting states (corrected) |
Designated state(s): AL AT BE BG CH CY CZ DE DK EE ES FI FR GB GR HR HU IE IS IT LI LT LU LV MC MK MT NL NO PL PT RO RS SE SI SK SM TR |
|
| STAA | Information on the status of an ep patent application or granted ep patent |
Free format text: STATUS: EXAMINATION IS IN PROGRESS |