EP4345283A1 - Verfahren und vorrichtung zur regelung einer turbine, computerprogramm - Google Patents
Verfahren und vorrichtung zur regelung einer turbine, computerprogramm Download PDFInfo
- Publication number
- EP4345283A1 EP4345283A1 EP23198027.7A EP23198027A EP4345283A1 EP 4345283 A1 EP4345283 A1 EP 4345283A1 EP 23198027 A EP23198027 A EP 23198027A EP 4345283 A1 EP4345283 A1 EP 4345283A1
- Authority
- EP
- European Patent Office
- Prior art keywords
- orientation
- turbine
- blades
- control
- mod
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Granted
Links
Images






Classifications
-
- F—MECHANICAL ENGINEERING; LIGHTING; HEATING; WEAPONS; BLASTING
- F03—MACHINES OR ENGINES FOR LIQUIDS; WIND, SPRING, OR WEIGHT MOTORS; PRODUCING MECHANICAL POWER OR A REACTIVE PROPULSIVE THRUST, NOT OTHERWISE PROVIDED FOR
- F03B—MACHINES OR ENGINES FOR LIQUIDS
- F03B3/00—Machines or engines of reaction type; Parts or details peculiar thereto
- F03B3/12—Blades; Blade-carrying rotors
- F03B3/14—Rotors having adjustable blades
-
- F—MECHANICAL ENGINEERING; LIGHTING; HEATING; WEAPONS; BLASTING
- F03—MACHINES OR ENGINES FOR LIQUIDS; WIND, SPRING, OR WEIGHT MOTORS; PRODUCING MECHANICAL POWER OR A REACTIVE PROPULSIVE THRUST, NOT OTHERWISE PROVIDED FOR
- F03B—MACHINES OR ENGINES FOR LIQUIDS
- F03B15/00—Controlling
- F03B15/02—Controlling by varying liquid flow
- F03B15/04—Controlling by varying liquid flow of turbines
- F03B15/06—Regulating, i.e. acting automatically
- F03B15/16—Regulating, i.e. acting automatically by power output
-
- F—MECHANICAL ENGINEERING; LIGHTING; HEATING; WEAPONS; BLASTING
- F03—MACHINES OR ENGINES FOR LIQUIDS; WIND, SPRING, OR WEIGHT MOTORS; PRODUCING MECHANICAL POWER OR A REACTIVE PROPULSIVE THRUST, NOT OTHERWISE PROVIDED FOR
- F03B—MACHINES OR ENGINES FOR LIQUIDS
- F03B3/00—Machines or engines of reaction type; Parts or details peculiar thereto
- F03B3/16—Stators
- F03B3/18—Stator blades; Guide conduits or vanes, e.g. adjustable
- F03B3/183—Adjustable vanes, e.g. wicket gates
-
- F—MECHANICAL ENGINEERING; LIGHTING; HEATING; WEAPONS; BLASTING
- F05—INDEXING SCHEMES RELATING TO ENGINES OR PUMPS IN VARIOUS SUBCLASSES OF CLASSES F01-F04
- F05B—INDEXING SCHEME RELATING TO WIND, SPRING, WEIGHT, INERTIA OR LIKE MOTORS, TO MACHINES OR ENGINES FOR LIQUIDS COVERED BY SUBCLASSES F03B, F03D AND F03G
- F05B2270/00—Control
- F05B2270/10—Purpose of the control system
- F05B2270/20—Purpose of the control system to optimise the performance of a machine
-
- F—MECHANICAL ENGINEERING; LIGHTING; HEATING; WEAPONS; BLASTING
- F05—INDEXING SCHEMES RELATING TO ENGINES OR PUMPS IN VARIOUS SUBCLASSES OF CLASSES F01-F04
- F05B—INDEXING SCHEME RELATING TO WIND, SPRING, WEIGHT, INERTIA OR LIKE MOTORS, TO MACHINES OR ENGINES FOR LIQUIDS COVERED BY SUBCLASSES F03B, F03D AND F03G
- F05B2270/00—Control
- F05B2270/30—Control parameters, e.g. input parameters
- F05B2270/335—Output power or torque
Definitions
- the invention relates to a method and a device for adjusting a double-adjustable reaction turbine, as well as a computer program for their implementation.
- the field of the invention relates in particular to electricity production turbines.
- Such double-adjustable reaction turbines are known, namely with adjustment of the orientation of the blades and with adjustment of the orientation of the guide vanes; said guide vanes also being called winnowing.
- Index Test The set of measures making it possible to find and/or optimize the conjugation laws of these two settings is called Index Test, standardized by the international standard CE160041.
- the flow defines the kinematics of the fluid in the turbine body. It is therefore a priori a key quantity for a search for the best combination of valve and blade settings.
- the measurement of the fluid flow can be difficult to obtain, for example due to the accessibility to the measurement sections (fluid flow section or areas where the installation points of measurement sensors are located), the available distance of straight sections on the hydraulic circuit, etc.
- the installation of flow measurement means can be risky in terms of personal safety depending on the accessibility of the measurement sections.
- Measuring the fluid flow can also be costly in terms of equipment: depending on the design of the facilities, a trolley may be necessary to implement the sensors which must be multiplied in number depending on the flow section. In certain cases, the condition of the pressure taps also has a preponderant influence on the reliability and consistency of the results obtained.
- Such a fluid flow measurement installation requires human resources and, however, remains unreliable. Indeed, depending on the arrangements, the geometry of the measurement sections is not always verifiable (impossibility of making geometric measurements, combined with old or even incomplete plans) or include singularities geometry requiring measurement corrections, the distance between the turbine and the measurement section may be insufficient and does not allow the fluid to have an ideally laminar behavior avoiding hydraulic turbulence harmful to the measurement. The reliability of the measurements also relies on the measurement uncertainties and the metrological monitoring of the sensors involved in the measurement.
- the present invention aims to obtain a method and a device for adjusting the turbine, as well as a computer program for their implementation, which improve the current situation by proposing a control law which combines the adjustment of the blades and the adjustment of the valve, avoiding the measurement of fluid flow.
- the target electrical powers are equal to the electrical powers P having been measured and corresponding to the third points.
- the target electrical powers and the first iso-power points are calculated by the control module during the sixth sub-step by interpolation from the quadruplets (Y' p,j , Y' v,i , H, P) of data.
- the prescribed envelope around the initial conjugation law is formed by a zone between a lower envelope curve and an upper envelope curve, which are located respectively below and above the starting conjugation law according to the first blade orientation command.
- the lower envelope curve corresponds to the initial conjugation law, having been shifted by a first prescribed offset downwards according to the first blade orientation command
- the curve upper envelope corresponds to the initial conjugation law, having been shifted by a second prescribed offset upwards according to the first blade orientation command
- the second law is obtained by the control module from turbine flow measurements previously recorded for certain values of the first orientation command blades and/or the second control Y' v,i for orientation of the fluid valve guide vanes, or from a flow model for certain values of the first control for orientation of the blades and/or the second control Y' v,i for orientation of the fluid valve guide vanes.
- a third object of the invention is a computer program, comprising code instructions for implementing the method of adjusting a turbine as described above, when executed by a computer.
- Turbine 1 may be a turbine of a turbo-alternator for generating electricity or a turbine of an electricity generator, or other. As described below, the turbine 1 is a reaction with double adjustment Y p , Y v of the blades 12 and the guide vanes 14. The turbine 1 is controlled by regulating members 121, 141 for admitting fluid 141
- the turbine 1 comprises a rotation shaft 11, which is mounted to rotate in a frame 10 around a first axis 110 of rotation. Blades 12 are fixed on the rotation shaft 11, around it.
- the chassis 10 includes a fluid inlet path 101 (for example a spiral cover 101), in which fluid is sent towards the blades 12.
- the frame 10 includes a fluid outlet path 103, in which the fluid is sent from the blades 12.
- the blades 12 are located between the fluid inlet path 101 and the fluid outlet path 103.
- the fluid can be for example water, or other, such as steam, or air for a wind turbine.
- the turbine 1 is for example of the vertical shaft 11 type.
- the turbine 1 is for example of the horizontal shaft 11 type.
- Each blade 12 is rotatably mounted around the shaft 11 around a second axis of rotation 122 perpendicular to the first axis 110 of rotation.
- the second axes of rotation 122 of the blades 12 are spaced from each other around the first axis 110 of rotation.
- the blades 12 are identical to each other.
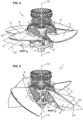
- the first ANGP orientation of each blade 12 (for example of the average plane 120 of each blade 12 or of a reference plane 120 of each blade 12) around its second axis of rotation 122 relative to a transverse plane 13, perpendicular to the first axis 110 of rotation, is adjustable according to a first command Y p for orientation of the blades 12 (or position Y p of the blades 12), as shown in figures 4 and 5 .
- the first ANGP orientation can be adjusted in common and in the same direction for all of the blades 12, by one (or more) first regulating member 121 (or first adjusting actuator 121), for example by a piston 121 provided on the shaft 11 (or by another regulating organ 121).
- the translation of the piston 121 along the first axis 110 of rotation rotates, via an articulation mechanism, the blades 12 each around their second axis of rotation 122, to adjust the first ANGP orientation of the blades 12 around of their second axis of rotation 122.
- the flow 102 of fluid drives the blades 12 and the shaft 11 in rotation around the first axis 110 of rotation.
- the rotation of the shaft 11 makes it possible, for example, to generate electricity in the case where the shaft 11 of the turbine 1 is connected to an alternator.
- the adjustment of the first ANGP orientation can be quantified in percentage of orientation (or in linear stroke in metric units of the piston 121, allowing the synchronization of the orientation of the blades 12).
- 100% for the first ANGP orientation corresponds to a configuration of the blades 12 all oriented according to a profile (called first maximum opening) maximizing the passage section between the blades 12, that is to say with the first ANGP orientation equal at a first prescribed maximum orientation.
- the adjustment of the first ANGP orientation or the first ANGP angle of the blades 12 between the average or reference plane 120 of the blade 12 and the normal plane 13 according to the figures 4 and 5 can also be located between a minimum value and a maximum value.
- valve guide vanes 14 are provided for valving the fluid.
- the function of the valve guide vanes 14 is to predetermine a volume of fluid passage between the fluid inlet path 101 and the fluid outlet path 103.
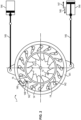
- Each valve guide vane 14 is rotatably mounted relative to the frame 10 around a third axis 142 of rotation (for example a whirlpool 142), which may for example be parallel to the first axis 110 of rotation.
- the third axes of rotation 142 guide vanes 14 are spaced apart from each other around the first axis 110 of rotation.
- the converging type geometry of the inlet path 101 makes it possible to preorient the speed vectors 102 of the fluid entering each passage section between two consecutive guide vanes 14.
- the valve guide vanes 14 are identical to each other.
- Each valve guide vane 14 is for example in the shape of a profiled hull.
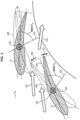
- the second valve orientation ANGV (or second angle ANGV) of each valve guide vane 14 (for example of the average plane 140 of each guide vane 14 or of a reference plane 140 of each guide vane 14) around its third axis 142 of rotation relative to a radial plane 143 passing through the first axis 110 of rotation, is adjustable according to a second control Y v for orientation of the guide vanes 14 of valve (or valve position Y v ), as shown in figure 2 And 3 .
- the second valve orientation ANGV can be adjusted in common and in the same direction for all of the valve guide vanes 14, and this by one (or more) second regulating member 141 (or second adjustment actuator 141), for example by a valve circle 141 connected to the guide vanes 14 or by another adjustment actuator 141.
- Each valve guide vane 14 is connected via a lever 148 and a link 149 to the valve circle 141.
- the valve circle 141 is further connected via one or more control rods 145 which can be translated by one or more servomotors 144 to rotate the valve circle 141 around the first axis 110 of rotation and to rotate the blades valves 14 each around their second axis of rotation 122, to adjust the second valve orientation ANGV of the guide vanes 14 around their third axis 142 of rotation.
- the set of guide vanes 14 is called valve or distributor.
- the second valve orientation ANGV makes it possible to adjust the fluid passage section between two consecutive valve guide vanes 14.
- the adjustment of the second valve orientation ANGV can be quantified as a percentage of opening of the guide vanes 14 (or in linear stroke in metric units of the servomotor(s) 144 which operate the valve circle 141).
- 0% for the second valve orientation ANGV corresponds to a configuration (called second minimum opening) of the guide vanes 14 all oriented according to a profile minimizing the passage section between the guide vanes 14 and for example not allowing any fluid to pass between the vanes guides 14 in a position 14F of closing of the guide vanes 14 touching each other as shown in broken lines at the Figure 3 .
- 100% for the second ANGV valve orientation corresponds to a configuration (called second maximum opening) of the guide vanes 14 all oriented according to a profile maximizing the passage section between the guide vanes 14, that is to say with the second ANGV valve orientation equal to a second ANGV valve orientation, maximum prescribed in the completely open or maximum position of the guide vanes 14.
- the arrow 146 of the figure 2 And 3 corresponds to the closing direction of the valve guide vanes 14 towards the closing position 14 F.
- Arrow 147 of figure 2 And 3 corresponds to the direction of opening of the valve guide vanes 14 from the closed position 14F towards the completely open or maximum position of the guide vanes 14.
- the device 100 for adjusting the turbine 1 according to the invention comprises a control module MOD, configured (programmed) to implement the steps described below of the adjustment method according to the invention, with reference to the figures 7 to 12 .
- the MOD control module may include several computers, and/or one or more processors, and/or one or more microprocessors, and/or one or more computers, and/or one or more computer programs, and/or one or more INT1, INT2 data input interfaces, and/or one or more INT3 data output interfaces, or others.
- the MOD module is based on an iso-power method for determining the conjugation laws of the blades 12 and valve control of the guide vanes 14 of the double-adjusted reaction turbines 1.
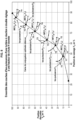
- the control module MOD determines for a plurality of target electrical powers P 1 , P 2 , P 3 , P 4 , P 5 , ... P n of the turbine 1, respectively of the first sets Y1, Y2, Y3, Y4, Y5,... Yn of combinations Y p , Y v of first values of the first control Y p of orientation of the blades 12 and of first values of the second control Y v of orientation guide vanes 14 for fluid valves, as shown by way of example in figure 8 .
- Each target power P 1 , P 2 , ... P n can be prescribed in the control module MOD.
- P n corresponds to a value of electrical power, which can be produced by the turbine 1.
- These first sets Y1, Y2, ... Yn of combinations Y p , Y v of first values of the first control Y p for orientation of the blades 12 and first values of the second control Y v for orientation of the guide vanes 14 for fluid valve are called sets or curves Y1, Y2, ... Yn of first points Y p , Y v of iso-power.
- Each set Y1, Y2, ... Yn of first iso-power points Y p , Y v corresponds to one of the target electrical powers P 1 , P 2 , ... P n of turbine 1.
- P n can be prescribed.
- Each set or curve Y1, Y2, ... Yn of first iso-power points Y p , Y v gives a first value of the first control Y p for orientation of the blades 12, which is decreasing as a function of the first value of the second control Y v for orientation of the fluid valve guide vanes 14.
- FIG. 11 An example of a curve Y1 of first points Y p , Y v of iso-power for the target electrical power P 1 is represented in Figure 11 .
- This curve Y1 passes through the first iso-power points ⁇ Y v1 , Y p1 ⁇ , ⁇ Y v2 , Y p2 ⁇ , ⁇ Y v3 , Y p3 ⁇ , ⁇ Y v4 , Y p4 ⁇ and ⁇ Y v5 , Y p5 ⁇ for the target electrical power P 1 .
- the control module MOD determines, for each target electrical power P 1 , P 2 , ... P n and among the first points Y p , Y v of iso-power of each set Y1, Y2, ... Yn, the first point INF(Y p , Y v ) of iso-power having a maximum slope break in absolute value, called point INF(Y p , Y v ) of optimum adjustment of each target electrical power P 1 , P 2 , ... P n , as shown by way of example in figure 8 .
- the first iso-power point INF(Y p , Y v ) of optimum adjustment is that of these first points Y p , Y v of iso-power which presents a break in maximum slope in absolute value with respect to the first neighboring points Y p , Y v of iso-power, each slope joining each first point Y p , Y v of iso-power power at its first point Y p , Y v of neighboring iso-power.
- the control module MOD determines the first point INF(Y p , Y v ) of optimum adjustment iso-power by detecting, for each first point INF(Y p , Y v ) of iso-power , if the change in slope is greater than a prescribed slope value, having been set by the user on the INT1 interface of the MOD control module.
- the number n of target electrical powers P 1 , P 2 , ... P n can for example be greater than or equal to 2 or 5 or others, and can for example be less than or equal to 10 or even greater than or equal to 10
- the number of first points Y p , Y v of iso-power in each set Y1, Y2, ... Yn can for example be greater than or equal to 2 or 3 or others, and can for example be less than or equal to 8 or even greater than or equal to 8.
- Each target electrical power P 1 , P 2 , ... P n is greater than or equal to a minimum admissible power prescribed for the proper operation of the turbine 1 for a given head H and is less than or equal to a maximum power prescribed for the proper operation of the turbine 1 for a given head H.
- control module MOD records in its memory MEM or MEM data base the points INF(Y p , Y v ) of optimum adjustment for the plurality of target electrical powers P 1 , P 2 , ... P n of turbine 1.
- the points INF(Y p , Y v ) of optimum adjustment for the plurality of target electrical powers P 1 , P 2 , ... P n of the turbine 1 form an optimal law (or optimal cam) for conjugation of the blades 12 and guide vanes 14.
- the conjugation cams are the laws of the best combinations of the first control Y p for orientation of the blades 12 of the regulating member 121 and first values of the second control Y v for orientation of the guide vanes 14 of valve of fluid from the regulating member 141 at a given drop height H, making it possible to maximize the overall efficiency of the turbine 1 for each flow rate of the turbine 1.
- the invention makes it possible to obtain the cams for conjugating the settings Y p , Y v of the blades 12 and the guide vanes 14 without having to measure the flow rate of the turbine 1 for each of these settings Y p , Y v .
- measuring the flow rate Q of the fluid can be difficult to obtain, for example due to the accessibility to the flow measurement sections (fluid flow section or areas where the sensor installation points are located). measurement), the available distance of straight sections on the hydraulic circuit, etc.
- the installation of flow measurement means can be risky in terms of personal safety depending on the accessibility of the measurement sections.
- Measuring the flow rate Q of the fluid can also be costly in terms of equipment: depending on the design of the arrangements, a trolley may be necessary for the implementation of the flow sensors which must be multiplied in number according to the flow section.
- the condition of the pressure taps also has a preponderant influence on the reliability and consistency of the results obtained.
- Such a flow measurement installation mobilizes human resources and, however, remains unreliable.
- the geometry of the flow measurement sections are not always verifiable (impossibility of making geometric measurements, combined with old or even incomplete plans) or include geometric singularities requiring measurement corrections; the distance between the turbine and the flow measurement section may be insufficient and does not allow the fluid to have an ideally laminar behavior avoiding hydraulic turbulence harmful to the measurement.
- the reliability of flow measurements also relies on measurement uncertainties and metrological monitoring of the sensors involved in the measurement.
- Steps E1, E2 and E3 can be carried out for at least one given drop height H of the turbine 1, and for example for a single given drop height H or for each of several different given drop heights H.
- the height H of fall is defined by the difference in height between, on the one hand, a first fluid load line (for example water) located in the fluid inlet path 101 and a second fluid load line located in the fluid outlet channel 103.
- the points INF(Y p , Y v ) of optimum adjustment for the plurality of target electrical powers P 1 , P 2 , ... P n of the turbine 1 can therefore form the optimal law (or optimal cam) of conjugation of the blades 12 and guide vanes 14 for at least one given drop height H of the turbine 1, or for each of several different given drop heights H.
- the first step E1 may include the substeps described below.
- a first law L1 (Y p , Y v ) of initial conjugation is entered into the control module MOD, giving the first command Y p of orientation of the blades 12 as a function of the second control Y v for orientation of the fluid valve guide vanes 14.
- the law L1(Y p , Y v ) of starting conjugation corresponding to an initial programming of an AUT controller for controlling the turbine 1 for at least a given height H of drop of the turbine or for each of the different heights H of data drop.
- the first law L1 (Y p , Y v ) of initial conjugation is prescribed and pre-recorded in the MEM memory or MEM database of the MOD control module.
- the first sub-step E11 can include measuring by a first sensor CAP12, which is provided on or in the turbine 1 and which is connected to the data input interface INT of the control module MOD, the first ANGP orientation for the first command Y p for orientation of the blades 12 at 0% and for the first command Y p for orientation of the blades 12 at 100%.
- the first sub-step E11 can include measuring by a second sensor CAP14 of the turbine 1, which is provided on or in the turbine 1 and which is connected to the data input interface INT of the control module MOD, the second orientation ANGV for the second control Y v for orientation of the guide vanes 14 for 0% fluid valve and for the second control Y v for orientation of the guide vanes 14 for 100% fluid valve.
- the integer N can be greater than or equal to 4 or 5 and be less than or equal to 10.
- the invention can also be applied to values of N less than 4 or greater than 10.
- the integer M can be greater than or equal to 4 or 5 and be less than or equal to 10.
- the invention can also be applied to values of M less than 4 or greater than 10.
- the second points P2 of the grid are spaced at a prescribed pitch ⁇ (non-zero) along the second control Y v for orientation of the fluid valve guide vanes 14.
- ⁇ non-zero
- the second points P2 of the grid are spaced by a prescribed step ⁇ ' (non-zero) along the first control Y p for orientation of the blades 12.
- ⁇ ' non-zero
- the step ⁇ ' can be equal to the step ⁇ or be different from the step ⁇ .
- the prescribed envelope ENV around the law L1 (Y p , Y v ) of initial conjugation can be formed by a zone between a lower envelope curve ENV1 and an upper envelope curve ENV2.
- the lower envelope curve ENV1 is an increasing function of Y p as a function of Y v and is located below the law L1 (Y p , Y v ) of initial conjugation.
- the upper envelope curve ENV2 is another increasing function of Y p as a function of Y v and is located above the law L1 (Y p , Y v ) of initial conjugation.
- the lower envelope curve ENV1 corresponds to the law L1 (Y p , Y v ) of initial conjugation, having been shifted by a first prescribed offset downwards according to the first command Y p of orientation of the blades 12.
- the upper envelope curve ENV2 corresponds to the law L1 (Y p , Y v ) of initial conjugation, having been shifted by a second prescribed shift upwards according to the first orientation command Y p blades 12.
- the first offset can be equal in absolute value to the second offset.
- the envelope ENV1 and ENV2 curves could be different from the initial conjugation law L1 (Y p , Y v ) having been shifted.
- the control module MOD obtains the flow rate of the turbine 1 for each second point P2 from a second prescribed law, giving the value of the flow rate Q(Y p,j , Y v,i ) of turbine 1 as a function of Y p,j and Y v,i .
- the second law is prescribed in the command MOD module and may have been entered in the command MOD module. For example, the second law may have been obtained from flow measurements of the turbine 1 previously recorded or from charts giving the measured flow rate of the turbine 1, for certain values of the first command Y p for orientation of the turbines.
- the method according to the invention dispenses with a real-time measurement of the flow rate of the fluid in the turbine 1, but relies on pre-recorded measurements of the flow rate.
- the control module MOD selects, for each second point P2 having the coordinates Y p,j and Y v,i for i ranging from 1 to N and for j ranging from 1 to M, a third point P3 having coordinates Y' p,j and Y' v,i which correspond to those of the coordinates Y p,j and Y v,i which meet the criterion of the minimum in absolute value between the flow rate of each second point P2 and the flow rate of second neighboring points P2.
- Each third point P3 therefore minimizes the variation in the flow rate Q. This advantageously makes it possible to preserve the arrangements, the materials and the safety of third parties during the operation of the MOD control module.
- the coordinate Y' p,j is the first command Y p for orientation of the blades 12.
- the coordinate Y' v,i is the second command Y v for orientation of the fluid valve guide vanes 14.
- the control module MOD thus selects for each second point P2 the third neighboring point P3 which meets the following criterion, calculated by the control module MOD: min Q Y vi + 1 Y pj ⁇ Q Y vi Y pj ; Q Y vi + 1 Y pj + 1 ⁇ Q Y vi Y pj ; Q Y vi Y pj + 1 ⁇ Q Y vi Y pj ; Q Y vi Y pj ⁇ 1 ⁇ Q Y vi Y pj ; Q Y vi + 1 Y pj ⁇ 1 ⁇ Q Y vi Y pj ; Q Y vi + 1 Y pj ⁇ 1 ⁇ Q Y vi Y pj ; Q Y vi ⁇ 1 Y
- the MOD control module thus carries out an automatic exploration, point P2 after point P2, of the grid to select points P3 among points P2.
- This automatic exploration is also called routine.
- the starting point P2 of the routine can for example be the first minimum opening of the blades 12 at 0% and the second minimum opening at 0% of the guide vanes 11, for the turbine 1 considered.
- the starting point P2 of the routine could for example be the first maximum opening of the blades 12 at 100% and the second maximum opening of the guide vanes 11 at 100%, for the turbine 1 considered.
- the control module MOD regulates (or sends) to the turbine 1, via the data output interface INT3 of the module MOD connected to the regulating bodies 121 and 141 , for one or each of the given drop heights H, the second control Y' v,i for orientation of the fluid valve guide vanes 14, associated with the first control Y' p,j for orientation of the blades 12 according to each third point P3.
- Modification of the second control Y' v,i for orientation of the fluid valve guide vanes 14 of the regulating member 141 and of the first control Y' p,j for orientation of the blades 12 of the regulating member 121 is carried out automatically by the MOD control module according to waiting time, stabilization and data recording criteria during the execution of the routine to position at the third point P3.
- a so-called step-by-step mode allows you to move from a second command Y' v,i to another and from a first command Y' p,j to another on instruction entered by the user on the INT1 interface of the MOD control module (the following point P3 to be tested is always designated by the MOD module according to the criterion described previously).
- the routine may be interrupted (and restarted) at any time for reasons of safety and preservation of the turbine 1 tested as well as for the proper operation of the hydraulic system.
- an automatic mode makes it possible to move from a second command Y' v,i to another and from a first command Y' p,j to another automatically in a manner programmed in the MOD control module.
- the MOD control module can go from a second command Y' v,i to a first command Y' p,j either simultaneously or one after the other, depending on the control technology of the turbine tested. 1.
- a power measurement member or sensor CAPP provided on the turbine 1 measures an electrical power P produced by the turbine 1 (for example by measuring an electrical voltage V produced by the turbine 1 and by measuring an electric current I produced by the turbine 1, the measurement sensor CAPP may include an active power transducer TPA, as shown by way of example in figure 7 ) for each third point P3.
- the electrical power P measured by the CAPP measurement sensor is sent to the control module MOD, comprising an interface INT2 for receiving data from this measured electrical power P, this reception interface INT2 being connected to the CAPP measurement sensor.
- the MOD control module records quadruplets (Y' p,j , Y' v,i , H, P) of data giving in association the first command Y' p,j for orientation of the blades 12, the second command Y' v,i orientation of the fluid valve guide vanes 14, the at least one given drop height H and the electrical power P having been measured and corresponding to each third point P3, in the MEM memory or MEM data base.
- the control module MOD determines from the quadruplets (Y' p,j , Y' v,i , H, P) of data the target electrical powers P 1 , P 2 , ... P n and the first iso-power points Y p , Y v associated with the target electrical powers P 1 , P 2 , ... P n (first sets Y1, Y2, ... Yn).
- the target electrical powers P 1 , P 2 , ... P n can be equal to the electrical powers P having been measured and corresponding to the third points P3.
- control module MOD calculates during the sixth sub-step E16 the target electrical powers P 1 , P 2 , ... P n and the first points Y p , Y v of iso -power by interpolation from quadruplets (Y' p,j , Y' v,i , H, P) of data.
- each target power P 1 , P 2 , ... P n can be prescribed in the control module MOD.
- the MOD control module can sort the quadruplets (Y' p,j , Y' v,i , H, P) of data according to the electrical powers P.
- the MOD control module can retain for this target power P 1 , P 2 , ... P n the quadruplet (Y' p,j , Y' v, i , H, P) of data, the measured power P of which is closest to the target power P 1 , P 2 , ... P n , for example at more or less a predetermined value ⁇ P.
- control module MOD performs the second step E2 described above to determine the points INF(Y p , Y v ) for optimum adjustment of the target electrical powers P 1 , P 2 , ... P n .
- the first step E1 may include the substeps described below.
- the control module MOD regulates (or sends) the turbine 1 by the data output interface INT3 of the MOD module connected to the regulating organs 121 and 141, for one or each of the given drop heights H the first command Y p for orientation of the blades 12 successively to a first selected value Y pr of adjustment among several first prescribed values Y pr1 , Y pr2 , ..., Y prK for adjusting the first control Y p for orientation of the blades 12 (for example with a prescribed and non-zero step ⁇ " between these first prescribed values Y pr1 , Y pr2 , ... , Y prK setting).
- the power measurement member or sensor CAPP provided on the turbine 1 measures an electrical power P produced by the turbine 1 (for example by measuring an electrical voltage V produced by the turbine 1 and by measuring an electric current I produced by the turbine 1, the CAPP measurement sensor may include an active power transducer TPA, as shown as example Figure 7 ).
- the electrical power P measured by the measurement sensor CAPP is sent to the control module MOD, comprising an interface INT2 for receiving data from this measured electrical power P, this reception interface INT2 being connected to the measurement sensor CAPP.
- the MOD control module regulates (or sends) to the turbine 1 via the data output interface INT3 of the MOD module connected to the regulating bodies 121 and 141, for each first selected value Y for adjustment of the first control Y p for orientation of the blades 12 and for each given height H of drop of the turbine 1, the second control Y v for orientation of the guide vanes 14 for fluid valve successively to a second selected value Y vr for adjustment among several second values prescribed Y vr1 , Y vr2 , ..., Y vrL for adjusting the second control Y v for orientation of the guide vanes 14 for valving fluid (for example with a prescribed and non-zero step ⁇ ′′′ between these second prescribed values Y vr1 , Y vr2 , ...
- the control module MOD records in its MEM database quadruplets (Y pr , H, P s , Y vr ) of data giving each first value selected Y pr for adjusting the first control Y p for orientation of the blades 12 in association with the at least one given drop height H of the turbine 1, with the target electrical power P s equal to one of P 1 , P 2 , ... P n (for the integer s ranging from 1 to n) and with the second selected value Y vr for adjusting the second control Y v for orientation of the guide vanes 14 for fluid valve, for which the electrical power measured on turbine 1 is equal to the target electrical power P s .
- the control module MOD determines from the quadruplets (Y pr , H, P s , Y vr ) of data the target electrical powers P 1 , P 2 , ... P n and the first iso-power points Y p , Y v associated with the target electrical powers P 1 , P 2 , ... P n (first sets Y1, Y2, ... Yn).
- each target power P 1 , P 2 , ... P n can be prescribed in the control module MOD.
- the MOD control module can sort the quadruplets (Y pr , H, P s , Y vr ) of data according to the target electrical powers P s .
- control module MOD performs the second step E2 described above to determine the points INF(Y p , Y v ) for optimum adjustment of the target electrical powers P 1 , P 2 , ... P n .
- the MOD control module can be portable and can be added or connected to the AUT automaton controlling turbine 1 (control-command of turbine 1).
- the MOD control module makes it possible both to control the turbine 1 by controlling the regulating members 121 and 141, and to collect and analyze the data for the research and optimization of the conjugation cams in an automatic manner.
- the invention makes it possible to supply the conjugation cams more quickly than with the standardized method and flow measurement, with a greatly reduced impact on the operation and availability of turbines on the electrical network.
- the deployment of the MOD module can be considered rapid on the turbines tested and requires limited mobilization of resources for implementation (1 person compared to 2 to 4 people for a standardized IEC60041 flow measurement (reel, piezometric control, etc.). ); the operating constraints are also limited in time.
- the results i.e. the laws or conjugation cams
- a given turbine resulting from the use of this MOD module make it possible to ensure sustainable and optimal exploitation of these here, with a guarantee of hydromechanical durability.
- the MOD module is compatible and adaptable to any AUT automation of double-adjusted reaction turbines that we wish to optimize and operate at their best operating points.
- the MOD module allows the turbine to be controlled at all times. by collecting and recording the data from which it will be possible to determine and optimize these laws (or cams) of conjugations.
Landscapes
- Engineering & Computer Science (AREA)
- Chemical & Material Sciences (AREA)
- Combustion & Propulsion (AREA)
- Mechanical Engineering (AREA)
- General Engineering & Computer Science (AREA)
- Control Of Turbines (AREA)
- Control Of Water Turbines (AREA)
Applications Claiming Priority (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| FR2210040A FR3140404B1 (fr) | 2022-09-30 | 2022-09-30 | Procédé et dispositif de réglage d’une turbine , programme d’ordinateur |
Publications (2)
| Publication Number | Publication Date |
|---|---|
| EP4345283A1 true EP4345283A1 (de) | 2024-04-03 |
| EP4345283B1 EP4345283B1 (de) | 2025-09-17 |
Family
ID=84370131
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| EP23198027.7A Active EP4345283B1 (de) | 2022-09-30 | 2023-09-18 | Verfahren und vorrichtung zur regelung einer turbine, computerprogramm |
Country Status (3)
| Country | Link |
|---|---|
| EP (1) | EP4345283B1 (de) |
| CA (1) | CA3213913A1 (de) |
| FR (1) | FR3140404B1 (de) |
Citations (4)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| US4794544A (en) * | 1987-03-26 | 1988-12-27 | Woodward Governor Company | Method and apparatus for automatically index testing a kaplan turbine |
| DE4220255C1 (de) * | 1992-06-23 | 1993-12-23 | Voith Gmbh J M | Verfahren zum Optimieren des Wirkunggrades eines Maschinensatzes mit einer Turbine und einem Generator |
| EP0644331A1 (de) * | 1993-09-22 | 1995-03-22 | Sulzer - Escher Wyss AG | Verfahren zur Optimierung des Wirkungsgrades einer Wasserturbine |
| RU2743704C1 (ru) * | 2020-07-13 | 2021-02-24 | ООО «Ракурс-инжиниринг» | Способ определения координат точки комбинаторной зависимости поворотно-лопастной гидравлической турбины |
-
2022
- 2022-09-30 FR FR2210040A patent/FR3140404B1/fr active Active
-
2023
- 2023-09-18 EP EP23198027.7A patent/EP4345283B1/de active Active
- 2023-09-25 CA CA3213913A patent/CA3213913A1/fr active Pending
Patent Citations (4)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| US4794544A (en) * | 1987-03-26 | 1988-12-27 | Woodward Governor Company | Method and apparatus for automatically index testing a kaplan turbine |
| DE4220255C1 (de) * | 1992-06-23 | 1993-12-23 | Voith Gmbh J M | Verfahren zum Optimieren des Wirkunggrades eines Maschinensatzes mit einer Turbine und einem Generator |
| EP0644331A1 (de) * | 1993-09-22 | 1995-03-22 | Sulzer - Escher Wyss AG | Verfahren zur Optimierung des Wirkungsgrades einer Wasserturbine |
| RU2743704C1 (ru) * | 2020-07-13 | 2021-02-24 | ООО «Ракурс-инжиниринг» | Способ определения координат точки комбинаторной зависимости поворотно-лопастной гидравлической турбины |
Also Published As
| Publication number | Publication date |
|---|---|
| FR3140404A1 (fr) | 2024-04-05 |
| CA3213913A1 (fr) | 2024-03-30 |
| EP4345283B1 (de) | 2025-09-17 |
| FR3140404B1 (fr) | 2024-10-11 |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| EP3438448B1 (de) | Steuerung eines windparks | |
| Fleming et al. | Full-scale field test of wake steering | |
| CA2553880C (fr) | Controle des aubes de turbomachine | |
| FR3068139A1 (fr) | Procede d'acquisition et de modelisation par un capteur lidar d'un champ de vent incident | |
| Brugger et al. | Lidar measurements of yawed-wind-turbine wakes: characterization and validation of analytical models | |
| EP2075721B1 (de) | Auswahlverfahren für die Anordnung von Sektoren eines Leitkranzes für Turbomaschinen | |
| FR2524938A1 (fr) | Procede de regulation du rapport de melange des propergols pour un moteur a propergols liquides par mesure des debits et regulateurs pour sa mise en oeuvre | |
| EP1959130A2 (de) | Verfahren zur Optimierung eines Windturbinenbetriebs | |
| EP4193318A1 (de) | Verfahren zum bau eines windparks in einem vorgegebenen raum | |
| EP4345283B1 (de) | Verfahren und vorrichtung zur regelung einer turbine, computerprogramm | |
| EP1508691A1 (de) | Windkraftanlage mit waagerechter Welle und Verfahren zur Messung des Aufwärtsströmungswinkels | |
| Schlipf et al. | Systems engineering for lidar-assisted control: a sequential approach | |
| FR2556773A1 (fr) | Dispositif de controle des performances thermiques d'un systeme turbo-alternateur a vapeur | |
| EP3862560B1 (de) | Verfahren zur bestimmung der windgeschwindigkeit in der rotorebene einer windkraftanlage | |
| EP4442992A1 (de) | Verfahren zur steuerung eines windparks mittels optimierungsverfahren | |
| FR3116081A1 (fr) | Aube de turbomachine comprenant un connecteur électrique placé au niveau d’un pivot | |
| FR2563278A1 (fr) | Procede pour commander, regler ou controler des turbo-machines thermiques suivant le critere de la sollicitation des materiaux | |
| WO2022064151A1 (fr) | Procédé de caractérisation de fuite | |
| EP3862563A1 (de) | Verfahren zur bestimmung der windrichtung mithilfe eines laserfernerkennungssensors | |
| EP3995834B1 (de) | Verfahren zur bestimmung der windgeschwindigkeit in der rotorebene einer windkraftanlage | |
| WO2025186339A1 (fr) | Systeme de supervision d'un parc eolien | |
| FR2926643A1 (fr) | Unite de regulation et procede de regulation de l'ouverture d'un volet installe dans une conduite de debit massique. | |
| EP3985250B1 (de) | Verfahren zur bestimmung eines induktionsfaktors zwischen einer messebene und der ebene des rotors einer windkraftanlage | |
| WO2024061627A1 (fr) | Methode de construction d'une ferme eolienne avec contraintes d'alignement | |
| EP3969737B1 (de) | Verfahren und vorrichtung zur schätzung und verwendung einer totzone eines turbomaschinenventils |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| PUAI | Public reference made under article 153(3) epc to a published international application that has entered the european phase |
Free format text: ORIGINAL CODE: 0009012 |
|
| STAA | Information on the status of an ep patent application or granted ep patent |
Free format text: STATUS: REQUEST FOR EXAMINATION WAS MADE |
|
| 17P | Request for examination filed |
Effective date: 20230918 |
|
| AK | Designated contracting states |
Kind code of ref document: A1 Designated state(s): AL AT BE BG CH CY CZ DE DK EE ES FI FR GB GR HR HU IE IS IT LI LT LU LV MC ME MK MT NL NO PL PT RO RS SE SI SK SM TR |
|
| GRAP | Despatch of communication of intention to grant a patent |
Free format text: ORIGINAL CODE: EPIDOSNIGR1 |
|
| STAA | Information on the status of an ep patent application or granted ep patent |
Free format text: STATUS: GRANT OF PATENT IS INTENDED |
|
| INTG | Intention to grant announced |
Effective date: 20250509 |
|
| GRAS | Grant fee paid |
Free format text: ORIGINAL CODE: EPIDOSNIGR3 |
|
| GRAA | (expected) grant |
Free format text: ORIGINAL CODE: 0009210 |
|
| STAA | Information on the status of an ep patent application or granted ep patent |
Free format text: STATUS: THE PATENT HAS BEEN GRANTED |
|
| RIN1 | Information on inventor provided before grant (corrected) |
Inventor name: CAVALIER, JULIEN |
|
| AK | Designated contracting states |
Kind code of ref document: B1 Designated state(s): AL AT BE BG CH CY CZ DE DK EE ES FI FR GB GR HR HU IE IS IT LI LT LU LV MC ME MK MT NL NO PL PT RO RS SE SI SK SM TR |
|
| REG | Reference to a national code |
Ref country code: GB Ref legal event code: FG4D Free format text: NOT ENGLISH |
|
| REG | Reference to a national code |
Ref country code: CH Ref legal event code: EP |
|
| REG | Reference to a national code |
Ref country code: DE Ref legal event code: R096 Ref document number: 602023006740 Country of ref document: DE |
|
| REG | Reference to a national code |
Ref country code: IE Ref legal event code: FG4D Free format text: LANGUAGE OF EP DOCUMENT: FRENCH |
|
| PGFP | Annual fee paid to national office [announced via postgrant information from national office to epo] |
Ref country code: AT Payment date: 20251020 Year of fee payment: 3 Ref country code: FR Payment date: 20250926 Year of fee payment: 3 |
|
| PGFP | Annual fee paid to national office [announced via postgrant information from national office to epo] |
Ref country code: DE Payment date: 20251015 Year of fee payment: 3 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: NO Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20251217 |
|
| REG | Reference to a national code |
Ref country code: LT Ref legal event code: MG9D |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: FI Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20250917 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: HR Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20250917 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: GR Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20251218 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: SE Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20250917 |
|
| REG | Reference to a national code |
Ref country code: NL Ref legal event code: MP Effective date: 20250917 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: LV Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20250917 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: BG Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20250917 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: RS Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20251217 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: NL Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20250917 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: SM Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20250917 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: ES Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20250917 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: RO Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20250917 Ref country code: IT Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20250917 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: IS Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20260117 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: CZ Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20250917 Ref country code: PT Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20260119 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: PL Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20250917 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: EE Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20250917 Ref country code: SK Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20250917 |