EP4438538A1 - Enrouleur de fil - Google Patents
Enrouleur de fil Download PDFInfo
- Publication number
- EP4438538A1 EP4438538A1 EP24155728.9A EP24155728A EP4438538A1 EP 4438538 A1 EP4438538 A1 EP 4438538A1 EP 24155728 A EP24155728 A EP 24155728A EP 4438538 A1 EP4438538 A1 EP 4438538A1
- Authority
- EP
- European Patent Office
- Prior art keywords
- holding unit
- yarn
- pulley
- movable
- yarns
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Pending
Links
Images








Classifications
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B65—CONVEYING; PACKING; STORING; HANDLING THIN OR FILAMENTARY MATERIAL
- B65H—HANDLING THIN OR FILAMENTARY MATERIAL, e.g. SHEETS, WEBS, CABLES
- B65H57/00—Guides for filamentary materials; Supports therefor
- B65H57/003—Arrangements for threading or unthreading the guide
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B65—CONVEYING; PACKING; STORING; HANDLING THIN OR FILAMENTARY MATERIAL
- B65H—HANDLING THIN OR FILAMENTARY MATERIAL, e.g. SHEETS, WEBS, CABLES
- B65H54/00—Winding, coiling, or depositing filamentary material
- B65H54/02—Winding and traversing material on to reels, bobbins, tubes, or like package cores or formers
- B65H54/28—Traversing devices; Package-shaping arrangements
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B65—CONVEYING; PACKING; STORING; HANDLING THIN OR FILAMENTARY MATERIAL
- B65H—HANDLING THIN OR FILAMENTARY MATERIAL, e.g. SHEETS, WEBS, CABLES
- B65H54/00—Winding, coiling, or depositing filamentary material
- B65H54/02—Winding and traversing material on to reels, bobbins, tubes, or like package cores or formers
- B65H54/40—Arrangements for rotating packages
- B65H54/54—Arrangements for supporting cores or formers at winding stations; Securing cores or formers to driving members
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B65—CONVEYING; PACKING; STORING; HANDLING THIN OR FILAMENTARY MATERIAL
- B65H—HANDLING THIN OR FILAMENTARY MATERIAL, e.g. SHEETS, WEBS, CABLES
- B65H54/00—Winding, coiling, or depositing filamentary material
- B65H54/70—Other constructional features of yarn-winding machines
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B65—CONVEYING; PACKING; STORING; HANDLING THIN OR FILAMENTARY MATERIAL
- B65H—HANDLING THIN OR FILAMENTARY MATERIAL, e.g. SHEETS, WEBS, CABLES
- B65H57/00—Guides for filamentary materials; Supports therefor
- B65H57/16—Guides for filamentary materials; Supports therefor formed to maintain a plurality of filaments in spaced relation
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B65—CONVEYING; PACKING; STORING; HANDLING THIN OR FILAMENTARY MATERIAL
- B65H—HANDLING THIN OR FILAMENTARY MATERIAL, e.g. SHEETS, WEBS, CABLES
- B65H57/00—Guides for filamentary materials; Supports therefor
- B65H57/28—Reciprocating or oscillating guides
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B65—CONVEYING; PACKING; STORING; HANDLING THIN OR FILAMENTARY MATERIAL
- B65H—HANDLING THIN OR FILAMENTARY MATERIAL, e.g. SHEETS, WEBS, CABLES
- B65H2701/00—Handled material; Storage means
- B65H2701/10—Handled articles or webs
- B65H2701/17—Nature of material
- B65H2701/174—Textile; fibres
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B65—CONVEYING; PACKING; STORING; HANDLING THIN OR FILAMENTARY MATERIAL
- B65H—HANDLING THIN OR FILAMENTARY MATERIAL, e.g. SHEETS, WEBS, CABLES
- B65H2701/00—Handled material; Storage means
- B65H2701/30—Handled filamentary material
- B65H2701/31—Textiles threads or artificial strands of filaments
- B65H2701/313—Synthetic polymer threads
- B65H2701/3132—Synthetic polymer threads extruded from spinnerets
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B65—CONVEYING; PACKING; STORING; HANDLING THIN OR FILAMENTARY MATERIAL
- B65H—HANDLING THIN OR FILAMENTARY MATERIAL, e.g. SHEETS, WEBS, CABLES
- B65H2701/00—Handled material; Storage means
- B65H2701/30—Handled filamentary material
- B65H2701/38—Thread sheet, e.g. sheet of parallel yarns or wires
Definitions
- the present invention relates to a yarn winder.
- Patent Literature 1 Japanese Laid-Open Patent Publication No. 2017-114573 recites a yarn winder configured to wind yarns onto bobbins aligned in a predetermined arrangement direction, respectively.
- the yarn winder includes fulcrum guides (yarn guides) provided to correspond to the respective bobbins.
- the yarn winder further includes a yarn threading member (yarn threading mechanism) by which the yarns are threaded to the respective yarn guides.
- the yarn threading mechanism includes holding units configured to hold the yarns in a separated manner. An operator causes the holding units to hold the running yarns, and then moves the holding units at least in the arrangement direction. As a result, the yarns are threaded to the yarn guides one by one.
- the inventors of the subject application are trying to improve yarn threading mechanisms in order to simplify the above-described yarn threading and to shorten the time required for the yarn threading.
- a driving mechanism by which a holding unit holding yarns is moved without human power has been developed.
- an adjustment mechanism that allows an operator to manually adjust the position of a holding unit when yarns are held by the holding unit has been developed.
- An object of the present invention is to achieve positional adjustment of a holding unit of a yarn threading mechanism with a small power.
- the driving source of the driving mechanism in the non-actuated state, it becomes possible to manually move the movable portion connected to the holding unit. More specifically, when the driving source is in the non-actuated state, if the operator applies a force to the holding unit (and the movable body), the rotation member supported by the movable portion can rotate through the transmission mechanism and move in the first direction along the extending member. In other words, manual movement in the first direction of the holding unit is allowed.
- the resistance force e.g., friction force
- the driving mechanism of the present invention is a mechanism that applies the known principle of movable pulley, as described below.
- the rotation member is equivalent to the movable pulley.
- the resistance force is equivalent to the gravity acting on a weight hanging down from the movable pulley.
- the extending member is equivalent to a string supported by the ceiling and wound onto the movable pulley.
- the force with which the rotating rotation member is supported by the extending member is equivalent to a force with which the ceiling supports the movable pulley.
- the force applied to the holding unit and the movable body in the first direction is equivalent to a force with which a hand of the operator pulls the string.
- the first distance is equivalent to the distance at which a hand of the operator pulls the string.
- the second distance is equivalent to the moving distance of the movable pulley. Based on the principle, while the first distance is increased, the force required to be applied to the holding unit is decreased. (Details will be given in the embodiment below.) As a result, the holding unit provided in the yarn threading mechanism can be positionally adjusted with a small force.
- the yarn winder of the first aspect is arranged such that, when the driving source is in the non-actuated state, the yarn threading mechanism is arranged so that the position of the holding unit in the first direction is manually adjustable between a predetermined capture preparation position and a capturing position which is on one side in the first direction of the capture preparation position and where capture of the yarns is possible, and when the driving source is in the actuated state, the yarn threading mechanism being capable of threading the yarns held by the holding unit to the respective yarn guides by moving the holding unit from the capturing position to a yarn threading start position that is on the one side of the capturing position in the first direction and further moving the holding unit to a yarn threading completion position that is on the other side of the yarn threading start position in the first direction.
- the holding unit when moving the holding unit from the capture preparation position to the capturing position, it is possible to manually adjust the position of the holding unit in a delicate manner, as the driving source is switched to the non-actuated state. Furthermore, by putting the driving source in the actuated state, it is possible to perform yarn threading without manual intervention, by using the yarn threading mechanism. Therefore, the time and labor required for yarn threading can be reduced.
- the yarn winder of the second aspect is arranged such that the driving source includes an air cylinder configured to move the movable portion relative to the fixed portion by using pressure of compressed air, the air cylinder includes a cylinder main body that is the fixed portion and a piston that is the movable portion, the cylinder main body includes a first piston chamber and a second piston chamber that is provided to be opposite to the first piston chamber over the piston, and as the compressed air is discharged from both of the first piston chamber and the second piston chamber, the air cylinder is switched to the non-actuated state.
- the driving source includes an air cylinder configured to move the movable portion relative to the fixed portion by using pressure of compressed air
- the air cylinder includes a cylinder main body that is the fixed portion and a piston that is the movable portion
- the cylinder main body includes a first piston chamber and a second piston chamber that is provided to be opposite to the first piston chamber over the piston
- the driving mechanism and the adjustment mechanism by utilizing an air cylinder which is typically inexpensive as compared to, for example, a motor-driven cylinder and a hydraulic cylinder. Therefore, it is possible to reduce the component cost of the yarn winder.
- the yarn winder of any one of the first to third aspects is arranged such that the transmission mechanism includes: a base member which is movable together with the movable portion; a first rotated member which is provided on the downstream side of the rotation member in the transmission direction and which is rotatably supported by the base member; a second rotated member which is provided to be side by side with the first rotated member in the first direction and which is rotatably supported by the base member; and a wound member which has an extending portion extending in the first direction, the movable body being fixed to the extending portion, and the wound member being allowed to be wound onto the first rotated member and the second rotated member.
- the adjustment mechanism may have, for example, a pinion provided as a rotation member, a first rack provided as an extending member, and a second rack that is provided as a part of the transmission mechanism, extends in the first direction, and is movable integrally with the holding unit.
- the moving distance of the second rack in the first direction is long, and hence there is a risk that the leading end of the second rack may unintentionally protrude as compared to the leading end of the first rack in the first direction. Therefore, it may be necessary to secure a wide area in which the second rack can move in the first direction, which may result in upsizing of the yarn winder.
- the first rotated member and the second rotated member are rotatably supported by the base member. Furthermore, the wound member is wound around the first rotated member and the second rotated member.
- the first rotated member, the second rotated member, the wound member, and the movable body can be arranged so that they fit within an area that is approximately the same size as a range in which the base member extends in the first direction. Furthermore, the moving distance in the first direction of the base member is equal to the moving distance in the first direction of the movable portion. This suppresses the traveling range of the transmission mechanism to be short in the first direction. Therefore, increase in size of the yarn winder can be suppressed in the first direction.
- the yarn winder of the fourth aspect is arranged such that the transmission mechanism includes a third rotated member which is provided to be rotatable together with the rotation member and is provided on the upstream side of the first rotated member and the second rotated member in the transmission direction, and in a predetermined second direction orthogonal to both the first direction and a rotational axis direction of the third rotated member, the rotation axis center of the third rotated member is positionally different from the rotation axis center of the first rotated member and the rotation axis center of the second rotated member.
- the transmission mechanism includes a third rotated member which is provided to be rotatable together with the rotation member and is provided on the upstream side of the first rotated member and the second rotated member in the transmission direction, and in a predetermined second direction orthogonal to both the first direction and a rotational axis direction of the third rotated member, the rotation axis center of the third rotated member is positionally different from the rotation axis center of the first rotated member and the rotation axi
- the position of the third rotated member in the second direction can be set freely to some degree.
- the positions of the rotation member and the extending member in the second direction can be set freely to some degree. Therefore, it is possible to easily avoid interference between the transmission mechanism and the extending member.
- the yarn winder of the fifth aspect is arranged such that a pitch circle diameter of the third rotated member is substantially identical with a pitch circle diameter of the rotated member.
- the pitch circle diameter of the third rotated member is too short as compared to the pitch circle diameter of the rotated member, there is a risk that the force required to manually move the holding unit will become too large.
- the pitch circle diameter of the third rotated member is too long as compared to the pitch circle diameter of the rotation member, there is a risk that the force required to move the holding unit by the driving source will become too large. This makes it easy to achieve both the reduction of the force required to manually move the holding unit and the suppression of increase in force required to move the holding unit by the driving source.
- the up-down direction (second direction in the present invention) is a vertical direction in which the gravity acts.
- the left-right direction (third direction in the present invention) is a direction orthogonal to the up-down direction and is a direction in which paired winding units 5 oppose each other.
- the front-rear direction (arrangement direction and first direction of the present invention) is a direction which is orthogonal to both the up-down direction and the left-right direction, and is a direction in which bobbins B (described later) are aligned.
- the rear side corresponds to one side in the first direction of the present invention.
- the front side corresponds to the other side in the first direction of the present invention.
- a direction in which each yarn Y (described later) runs will be referred to as a yarn running direction.
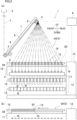
- FIG. 1 is a front view of the spun yarn take-up machine 1.
- FIG. 2(a) is a side view of the spun yarn take-up machine 1.
- FIG. 2(a) shows one (winding unit 5A) of a later-described pair of winding units 5.
- the spun yarn take-up machine 1 is configured to simultaneously form packages P by taking up plural (e.g., 32 in the present embodiment) yarns Y spun out from a spinning apparatus 2 and winding the yarns Y onto bobbins B.
- Each yarn Y is, for example, a multi-filament yarn having filaments (not illustrated).
- each yarn Y may be formed of a single filament.
- Each filament is a synthetic fiber made of, e.g., polyester.
- the spun yarn take-up machine 1 includes, for example, a first godet roller 3, a second godet roller 4, a pair of winding units 5 (winding units 5A and 5B), and a controller 6.
- the first godet roller 3 and the second godet roller 4 are arranged to take up yarns Y and feed them to the downstream side in a yarn running direction.
- the first godet roller 3 and the second godet roller 4 are supported by, for example, a supporting body 7.
- the supporting body 7 extends, for example, obliquely rearward and upward from a position above front end portions of the paired winding units 5.
- the first godet roller 3 is a roller having a rotational axis substantially in parallel to the left-right direction.
- the first godet roller 3 is, for example, attached to a front end portion of the supporting body 7.
- the first godet roller 3 is rotationally driven by an unillustrated motor.
- the yarns Y spun out from the spinning apparatus 2 are sent to the second godet roller 4 while being aligned in the left-right direction and wound onto the first godet roller 3.
- the second godet roller 4 is a roller having a rotational axis substantially in parallel to the left-right direction.
- the second godet roller 4 is, for example, provided above and rearward of the first godet roller 3.
- the second godet roller 4 is rotationally driven by an unillustrated motor.
- the second godet roller 4 is, for example, attached to the supporting body 7.
- the second godet roller 4 is, for example, arranged to be movable in the extending direction of the supporting body 7.
- the second godet roller 4 is movable between a roller front position indicated by two-dot chain lines shown in FIG. 2(a) and a roller rear position indicated by solid lines shown in FIG. 2(a) , by a roller movement mechanism 9, for example.
- the roller front position is a position forward of and below the roller rear position and is close to the first godet roller 3 as compared to the roller rear position.
- the roller front position is a position of the second godet roller 4 where yarn placement to the second godet roller 4 is performed.
- the roller rear position is a position of the second godet roller 4 where a later-described winding operation is performed.
- Each of the yarns Y is sent from the first godet roller 3 to the second godet roller 4, and then sent to one of the paired winding units 5.
- a half of the yarns Y is sent to the winding unit 5A and the remaining half of the yarns Y is sent to the winding unit 5B.
- a yarn path of each yarn Y running from the first godet roller 3 to the second godet roller 4 extends obliquely upward and rearward.
- a regulatory guide 8 is provided between the first godet roller 3 and the second godet roller 4, for example.
- the regulatory guide 8 is provided to hold the yarns Y to be aligned in the left-right direction and to arrange the intervals in the left-right direction of the yarns Y to be equal to predetermined intervals.
- Each of the paired winding units 5 is configured to form packages P by winding the yarns Y onto the bobbins B.
- the winding unit 5A and the winding unit 5B are provided below the first godet roller 3 and the second godet roller 4.
- the winding unit 5A and the winding unit 5B are provided to be substantially symmetric in the left-right direction (i.e., plane symmetric) (see FIG. 1 ).
- Each of the winding units 5 winds a half of the yarns Y (e.g., 16 yarns in the present embodiment) sent from the second godet roller 4.
- the winding unit 5A winds the left 16 yarns YA whereas the winding unit 5B winds the right 16 yarns YB.
- the controller 6 is, for example, a typical computer and is configured to control the entire spun yarn take-up machine 1.
- the controller 6 is electrically connected to sections of the spun yarn take-up machine 1.
- the controller 6 is electrically connected to an operation unit (not illustrated) operated by an operator.
- the operation unit has, for example, unillustrated operation buttons.
- the controller 6 is arranged to control the sections based on a predetermined program.
- the controller 6 is arranged to be able to control the sections in accordance with, for example, an operator's operation of the operation unit.
- each of the paired winding units 5 includes a supporting frame 11, a turret 12, and two bobbin holders 13. As described above, the winding unit 5A and the winding unit 5B are substantially symmetric in the left-right direction. Unless otherwise stated, the description of each constituent feature is applicable to both the winding unit 5A and the winding unit 5B.
- the supporting frame 11 is a member extending in the front-rear direction.
- the supporting frame 11 is cantilevered by a base 14 that stands vertically.
- the supporting frame 11 protrudes forward from the base 14 (see FIG. 2 ).
- the turret 12 is a disc-shaped member having a rotational axis substantially parallel to the front-rear direction.
- the turret 12 is rotatably supported by the base 14.
- the turret 12 is rotationally driven by a turret motor which is not illustrated.
- Each of the two bobbin holders 13 is rotatably supported by the turret 12 and protrudes forward from the front surface of the turret 12.
- the rotational axes of the two bobbin holders 13 are substantially in parallel to the front-rear direction.
- two bobbin holders 13 When viewed in the front-rear direction, two bobbin holders 13 are provided to be point symmetric about the center of the turret 12 (see FIG. 1 ). To each bobbin holder 13, the bobbins B provided for the respective yarns Y are attached to be lined up in the front-rear direction. The bobbins B are rotatably supported by each of the two bobbin holder 13. Each of the two bobbin holders 13 is independently rotated and driven by an unillustrated winding motor.
- each winding unit 5 includes the base 14 (see FIG. 1 ).
- the disclosure is not limited to this.
- two supporting frames 11 and two turrets 12 of the respective winding units 5A and 5B may be attached to the same base (not illustrated).
- Each winding unit 5 includes guide units 15, traverse guides 16, and a contact roller 17.
- a guide supporter 18 is provided to extend in the front-rear direction (see FIG. 2(a) and FIG. 2(b) ).
- the guide units 15 are attached to the guide supporter 18 to be movable along the front-rear direction.
- the guide units 15 are provided to correspond to the respective bobbins B and are aligned along the front-rear direction.
- Each of the guide units 15 includes a main body 19 and a fulcrum guide 20 (yarn guide of the present invention).
- the main body 19 is attached to the guide supporter 18 to be movable.
- the fulcrum guide 20 is fixed to the main body 19.
- Each of the fulcrum guides 20 is a fulcrum about which a corresponding yarn Y is traversed by each traverse guide 16.
- the guide units 15 are movable between winding positions (distanced positions; see FIG. 2(a) ) where the yarns Y are wound onto the bobbins B and gathered positions (see FIG. 2(b) ) where the guide units 15 are close to one another in the front-rear direction as compared to the distanced positions.
- the guide units 15 that are adjacent to one another in the front-rear direction are connected with one another by an unillustrated belt.
- the rearmost guide unit 15 is movable in the front-rear direction by, for example, an unillustrated linear slider.
- the guide units 15 are movable between the distanced positions and gathered positions where the units are gathered on the front side as compared to the distanced positions. Yarn threading (described later) to the fulcrum guides 20 is performed when the fulcrum guides 20 are at the gathered positions.
- the traverse guides 16 are aligned in the front-rear direction.
- Each of the traverse guides 16 is driven by, for example, an unillustrated traverse motor, and traverses the corresponding yarn Y in the front-rear direction.
- the contact roller 17 has a rotational axis that extends substantially in parallel to the front-rear direction.
- the contact roller 17 is provided immediately above the upper bobbin holder 13.
- the contact roller 17 is configured to make contact with the surfaces of the packages P supported by the upper bobbin holder 13. With this, the contact roller 17 applies a contact pressure to the surface of each package P to adjust the shape of each package P.
- each of the paired winding units 5 structured as described above when the upper bobbin holder 13 is rotationally driven, the yarns Y traversed by the traverse guides 16 are wound onto the bobbins B, with the result that the packages P are formed.
- the turret 12 is rotated to switch the upper and lower positions of the two bobbin holders 13.
- the bobbin holder 13 having been at the lower position is moved to the upper position, which allows the yarns Y to be wound onto the bobbins B attached to the bobbin holder 13 having been moved to the upper position, to form packages P.
- the bobbin holder 13 to which the fully-formed packages P are attached is moved to the lower position.
- the fully-formed packages P are then collected by, e.g., an unillustrated package collector.
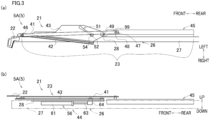
- FIG. 3(a) is a plan view of the yarn threading mechanism 21.
- FIG. 3(b) is a side view of the yarn threading mechanism 21.
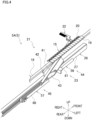
- FIG. 4 is a perspective view of the yarn threading mechanism 21 viewed from obliquely behind.
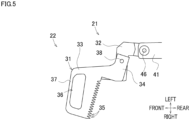
- FIG. 5 is a plan view of a later-described holding unit 22 and its surroundings.
- FIG. 6(a) illustrates a rear end portion of a later-described swing arm 43 and its surroundings.
- FIG. 6(b) is a schematic diagram showing the relationship between later-described air cylinders 56 and 57 and a path of compressed air. In FIG. 6(b) , both of the air cylinders 56 and 57 are shown in a single drawing.
- FIG. 7(a) and FIG. 7(b) shows a later-described yarn interval increaser 24.
- FIG. 7(a) is a side view of the yarn interval increaser 24.
- FIG. 7(b) shows the yarn interval increaser 24 viewed along an arrow VII(b) in FIG. 7(a) .
- each of the paired winding units 5 is provided with the yarn threading mechanism 21.
- the yarn threading mechanism 21 includes the holding unit 22 (see FIG. 3(a) to FIG. 5 ), a drive unit 23 (see FIG. 3(a) to FIG. 4 ), and the yarn interval increaser 24 (see FIG. 7(a) and FIG. 7(b) ).
- the yarn threading mechanism 21 is able to separate the yarns Y in the left-right direction by the yarn interval increaser 24 and to hold the separated yarns Y by the holding unit 22.
- the yarns Y are threaded to the respective fulcrum guides 20.
- the holding unit 22 and the drive unit 23 are provided in each winding unit 5. Between the winding unit 5A and the winding unit 5B, the holding units 22 and the drive units 23 are substantially symmetric in the left-right direction.
- the yarn interval increaser 24 is provided in the winding unit 5A and commonly used by the paired winding units 5. The following will describe only the yarn threading mechanism 21 provided in the winding unit 5A.
- the holding unit 22 is arranged to hold running yarns Y in a separated manner.
- the holding unit 22 of the winding unit 5A is arranged to be able to hold yarns YA (see FIG. 1 ).
- the holding unit 22 is attached to the winding unit 5A through the drive unit 23.
- a positionally-fixed supporting member 26 (see FIGs. 2 to 4 ) is provided between the supporting frame 11 and the guide supporter 18.
- the supporting member 26 includes, for example, as shown in FIG. 3(a) and FIG. 3(b) , a rod member 27 extending in the front-rear direction and a plate member 28 fixed to a front portion of the rod member 27.
- the holding unit 22 is attached to the supporting member 26 through the drive unit 23.
- the holding unit 22 includes, for example, a comb guide 31 and an interposed member 32 (see FIG. 5 ).
- the comb guide 31 is a plate member that is comb-shaped on the whole.
- the comb guide 31 includes a main body 33 and a connection part 34.
- the main body 33 has retaining grooves 35 in which the respective yarns Y are retained.
- the retaining grooves 35 are aligned at least in the left-right direction.
- the entrance of each retaining groove 35 is formed at a rear end portion of the main body 33, for example.
- the intervals of the entrances of the retaining grooves 35 in the direction in which the retaining grooves 35 are aligned are substantially identical with the intervals (predetermined intervals) in the left-right direction of the yarns Y, which are defined by the regulatory guide 8.
- a through hole 36 is formed at an intermediate portion of the main body 33 in the front-rear direction.
- the through hole 36 for example, penetrates the main body 33 in the up-down direction and extends in the left-right direction.
- a grip 37 holdable by the operator is formed at a front end portion of the main body 33, for example.
- the connection part 34 is a part connected to a left end portion of a rear end portion of the main body 33.
- connection part 34 is connected to the interposed member 32 through a shaft 38 that extends in the up-down direction.
- the position of the connecting portion 34 is fixed relative to the interposed member 32 by, for example, a fastener such as an unillustrated bolt. When the fastener is loosened, it may be possible for the comb guide 31 to swing about the axis 38 as the swing axis.
- the interposed member 32 is, for example, a roughly L-shaped member when viewed in the up-down direction.
- the interposed member 32 is fixed to a support arm 41 (described later) of the drive unit 23.
- the holding unit 22 can be adjusted in the front-rear direction by an operator under a predetermined condition. The details will be given later.
- the drive unit 23 is configured to move the holding unit 22.
- the drive unit 23 is attached to the supporting member 26.
- the drive unit 23 has a supporting arm 41, a guide rail 42, a swing arm 43, a swing driving source 44, and a front-rear driving mechanism 45 (a driving mechanism and an adjustment mechanism of the present invention) .
- the front-rear driving mechanism 45 is simply shown in a rectangular shape.
- the support arm 41 to which the holding unit 22 is attached is moved at least in the front-rear direction along the guide rail 42 on account of the operation of the front-rear driving mechanism 45.
- the guide rail 42 is able to change the direction of movement of the support arm 41 and the holding unit 22 by being swung together with the swing arm 43 by the swing driving source 44.
- the teeth 82a are configured to mesh with the teeth 81a of the rack 81.
- the pinion 82 is provided on the downstream side of the piston rod 68 and on the upstream side of the transmission mechanism 83 in the direction of transmission of the thrust force of the air cylinder 57.
- the direction of transmission of the thrust force of the air cylinder 57 is simply referred to as a transmission direction.
- the side close to the piston 67 is defined as the upstream side
- the side far from the piston 67 is defined as the downstream side.
- the transmission mechanism 83 is configured to transmit the thrust force of the air cylinder 57 to the holding unit 22. Furthermore, the transmission mechanism 83 is configured to transmit the force applied by the operator to the holding unit 22 to the piston rod 68 when the holding unit 22 is moved by the operator.
- the transmission mechanism 83 is provided downstream of the pinion 82 and upstream of the holding unit 22 in the transmission direction.
- the transmission mechanism 83 has a base member 91, a guide rail 92, a sliding member 93, a first pulley 94, a second pulley 95, a third pulley 96, a fourth pulley 97, an endless belt 98, and the aforementioned movable body 99.
- the first pulley 94 to the fourth pulley 97 are rotatably supported by the base member 91 that is movable together with the piston rod 68.
- the endless belt 98 is wound onto the first pulley 94 to the third pulley 96.
- the endless belt 98 is bent by the fourth pulley 97.
- the movable body 99 is fixed to the endless belt 98 and is connected to the holding unit 22.
- the long section 91a is a portion that extends from the front end to the rear end of the base member 91, for example.
- the long section 91a is positioned above the air cylinder 57, for example.
- the short section 91b is a part that extends downward from a rear end portion of the long section 91a, for example.
- the short section 91b is fixed to, for example, the rod end 69. This allows the base member 91 to move in the front-rear direction together with the piston rod 68.
- the base member 91 is capable of moving in the front-rear direction along the guide rail 92, together with the sliding member 93.
- the base member 91 supports the first pulley 94 to the fourth pulley 97 to be rotatable.
- Each of the first pulley 94 to the fourth pulley 97 is rotatably supported by the base member 91.
- the position of each of the first pulley 94 to the fourth pulley 97 is fixed relative to the base member 91.
- the rotational axis direction of each of the first pulley 94 to the fourth pulley 97 is, for example, substantially in parallel to the left-right direction.
- the first pulley 94 to the fourth pulley 97 for example, are arranged on the opposite side of the rack 81 and the pinion 82 over the base member 91 in the left-right direction.
- the first pulley 94 (a first rotated member of the present invention) is a pulley around which an endless belt 98 is wound.
- the first pulley 94 is, for example, rotatably supported at the front end portion of the long section 91a of the base member 91.
- the first pulley 94 is positioned above the air cylinder 57, for example.
- the third pulley 96 (the third rotated member of the present invention) is similar to the first pulley 94 and the second pulley 95, and is a roller on which the endless belt 98 is wound.
- the third pulley 96 is rotatable together with the pinion 82. More specifically, the third pulley 96 is configured to be coaxial with the pinion 82.
- the third pulley 96 is positioned upstream of the first pulley 94 and the second pulley 95 in the transmission direction.
- the pitch circle diameter of the third pulley 96 is substantially equal to the pitch circle diameter of the pinion 82.
- the third pulley 96 is rotatably supported by the short section 91b of the base member 91, for example.
- the third pulley 96 is, for example, provided directly below the second pulley 95.
- the third pulley 96 is arranged at substantially the same position as the second pulley 95 in the front-rear direction, for example.
- the rotation axis center of the third pulley 96 is positioned at a different location from the rotation axis centers of the first pulley 94 and the second pulley 95 in the up-down direction, for example.
- the third pulley 96 is positioned directly behind the rod end 69 of the air cylinder 57, for example.
- the endless belt 98 (a wound member of the present invention) is, for example, a known toothed belt.
- the endless belt 98 is wound around, for example, the first pulley 94 to the third pulley 96 (more specifically, for example, the belt is parallelly wound).
- the inner circumferential surface of the endless belt 98 is in contact with the first pulley 94 to the third pulley 96.
- a portion of the endless belt 98, which is provided between the first pulley 94 and the second pulley 95 in the front-rear direction and extends substantially linearly, is referred to as an extending portion 98e (see FIG. 9(a), FIG. 9(b) ) for the convenience of explanation.
- the endless belt 98 is arranged to overlap at least partially with the air cylinder 57 in the left-right direction. More specifically, for example, the entire region in the longitudinal direction of the endless belt 98 is arranged to extend, for example, on a virtual plane VPB that is orthogonal to the left-right direction and is different from the virtual plane VPA.
- the outer circumferential surface of the endless belt 98 is in contact with the fourth pulley 97.
- the endless belt 98 is bent by the fourth pulley 97 so as not to interfere with the air cylinder 57.
- the movable body 99 is a member fixed to the extending portion 98e of the endless belt 98.
- the movable body 99 is configured, for example, to sandwich the endless belt 98 in the thickness direction of the endless belt 98.
- the movable body 99 is fixed to the endless belt 98 by, for example, a fastener such as an unillustrated bolt.
- the movable body 99 may be fixed to the endless belt 98 by, for example, adhesion.
- the movable body 99 is capable of moving in the front-rear direction together with the extending portion 98e of the endless belt 98 when the endless belt 98 moves relative to the first pulley 94 to the fourth pulley 97.
- the movable body 99 moves relative to the rack 81 as the base member 91 moves in a parallel manner in the front-rear direction, and also moves relative to the first pulley 94 to the fourth pulley 97.
- the movable body 99 is connected to the holding unit 22, for example, via the above-described supporting arm 41 (see FIG. 3(a) ). This allows the holding unit 22 to be movable at least in the front-rear direction in accordance with the movement of movable body 99 in the front-rear direction.
- the state of the air cylinder 57 is in the above-described non-actuated state.
- a predetermined force F1 (see FIG. 9(b) ) that is substantially identical with the rearward force in magnitude is applied to the movable body 99 and the endless belt 98.
- the first pulley 94 to the fourth pulley 97 rotate as the endless belt moves.
- a force that is substantially identical with the force F1 in magnitude is applied to the first pulley 94 to the fourth pulley 97.
- the pinion 82 rotates together with the third pulley 96.
- the pitch circle diameter of the pinion 82 is substantially equal to the pitch circle diameter of the third pulley 96.
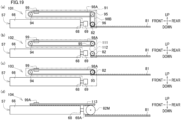
- a force that is substantially identical with the force F1 in magnitude (but opposite in direction to the force F1 in the front-rear direction) is applied to the teeth 82a of the pinion 82. Because the teeth 82a of the pinion 82 mesh with the teeth 81a of the rack 81, the pinion 82 receives a reaction force (force F2) from the rack 81 that is a force rotating and moving the pinion 82 rearward.
- the force F1 is substantially identical with the force F2 in magnitude.
- a resultant force of the forces F1 and F2 i.e., a force twice as much as the force F1 in magnitude and acting rearward acts on the piston rod 68 of the air cylinder 57.
- This resistance force mainly includes a friction force acting between the cylinder main body 66 and the piston 67 (see FIG. 6(b) ).
- the operator can move the holding unit 22 only by applying a force that is smaller than the force F3 (specifically, a force that is half as much as the force F3) to the holding unit 22.
- the moving distance in the front-rear direction of the movable body 99 is referred to as a first distance D1 (see FIG. 9(b) ).
- the moving distance of the piston rod 68 (and the pinion 82) in the same direction as the movable body 99 in the front-rear direction when the movable body 99 moves in the front-rear direction by the first distance D1 is referred to as a second distance D2 (see FIG. 9(b) ) for the sake of explanation.
- the second distance D2 is shorter than the first distance D1.
- the second distance D2 is half as long as the first distance D1.
- the pinion 82 is equivalent to the movable pulley.
- the resistance force is equivalent to the gravity acting on a weight hanging down from the movable pulley.
- the rack 81 is equivalent to a string supported by the ceiling.
- the force with which the rotating pinion 82 is supported (pushed back) by the rack 81 is equivalent to a force with which the ceiling supports the movable pulley.
- the force applied to the holding unit 22 (and the movable body 99) in the front-rear direction is equivalent to a force with which a hand of the operator pulls the string.
- the first distance D1 is equivalent to the distance at which a hand of the operator pulls the string.
- the second distance D2 is equivalent to the moving distance of the movable pulley. Based on the principle, while the first distance D1 is increased, the force required to be applied to the holding unit 22 is decreased. In this way, the operability of the holding unit 22 can be improved.
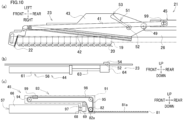
- FIGs. 10(a) to 10(c) illustrate a state in which the holding unit 22 is at a holding unit retracted position.
- FIGs. 11(a) to 11(f) illustrate operations until the yarns Y are pressed onto the separation roller 74 in yarn threading to the spun yarn take-up machine 1.
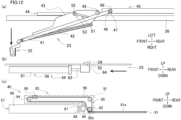
- FIGs. 12 (a) to 12(c) illustrate movement of the holding unit 22 to a capture preparation position (described later).
- FIGs. 13(a) to 13(c) illustrate fine adjustment of the position of the holding unit 22.
- FIG. 13(b) is an enlarged view of a region R shown in FIG. 13(a) .
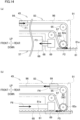
- FIGs. 14(a) and 14(b) are explanatory diagrams illustrating forces acting on sections of the front-rear driving mechanism 45. More specifically, FIG. 14 (a) shows the forces applied to sections of the front-rear driving mechanism 45 during manual operation of the holding unit 22 by the operator.
- FIG. 14 (b) is a diagram illustrating forces acting on sections of the front-rear driving mechanism 45 operated by compressed air.
- the left side of the sheet corresponds to the front side of the present embodiment
- the right side of the sheet corresponds to the rear side of the present embodiment.
- FIGs. 15(a) to 15(c) illustrate the retraction of the holding unit 22.
- FIGs. 16(a) to 16(c) illustrate the movement of the holding unit 22 to the yarn threading start position.
- FIGs. 17(a) to 17(c) are explanatory diagrams illustrating the movement of the holding unit 22 to the yarn threading completion position.
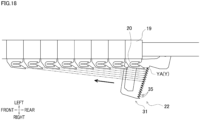
- FIG. 18 illustrates how the yarns Y are threaded to the fulcrum guides 20, respectively.
- the position of the rod end 64 and the pin 52 in the front-rear direction when the piston rod 63 of the air cylinder 56 is fully extended is referred to as an "extended position”.
- the position of the rod end 64 and the pin 52 in the front-rear direction when the piston rod 63 is fully contracted is called a "contracted position”.
- the position of the movable body 99 in the front-rear direction when the piston rod 68 of the air cylinder 57 is fully extended is referred to as a "rear end position”.
- the position of the movable body 99 in the front-rear direction when the piston rod 68 is fully contracted is referred to as a "front end position”.
- the operator threads the yarns Y to the first godet roller 3, the regulatory guide 8, and the second godet roller 4. Then the operator temporarily presses the yarns Y onto the separation roller 74. Furthermore, the operator causes the holding unit 22 to hold the yarns Y. Finally, the yarn threading mechanism 21 is driven under the control of the controller 6 to move the holding unit 22 from the aforementioned capturing position to the yarn threading start position, and further move the unit to the yarn threading completion position. As a result, the multiple yarns Y held by the holding unit 22 are threaded to the respective fulcrum guides 20.
- the piston rod 63 of the air cylinder 56 is at the extended position (see FIG. 10 (b) ).
- the movable body 99 is located at the above-described front end position (see FIG. 10(c) ).
- Each of the paired holding units 22 is therefore at the predetermined holding unit retracted position (see FIG. 3(a) and FIG. 10 (a) ).
- the separation roller 74 is at the roller retracted position (indicated by two-dot chain lines in FIG. 7(a) ).
- the operator performs a predetermined input operation to the input unit (not illustrated) of the controller 6.
- the controller 6 controls the sections of the spun yarn take-up machine 1 so that the state of the spun yarn take-up machine 1 is in a yarn threading preparation state described below. That is to say, the controller 6 moves the second godet roller 4 to the front position (see FIG. 11(a) ). Furthermore, the controller 6 moves the fulcrum guides 20 to the gathered positions (see e.g., FIG. 10(a) ).
- the operator operates the grip 73 of the yarn interval increaser 24 to rotate the rotation arm 72, so as to move the separation roller 74 from the roller retracted position to the roller contact position (see full lines in FIG. 7(a) and FIG. 11(a) ).
- the operator then sucks and holds the yarns Y (to be more specific, all of 32 yarns YA and YB) by using a suction gun SG (see FIG. 11(a) ) arranged to be able to suck and hold the yarns Y.
- a suction gun SG By operating the suction gun SG, the operator threads the yarns Y to the first godet roller 3, the regulatory guide 8, and the second godet roller 4 in this order (see FIG. 11(a) ).
- the operator operates the suction gun SG to move the leading end portion of the suction gun SG to a position below and to the right of the separation roller 74 (see FIGs. 11(b) and 11(c) ).
- the operator moves the yarns Y to a position immediately behind the separation roller 74 (see FIG. 11(d) ).
- the intervals of the yarns Y running from the regulatory guide 8 toward the suction gun SG narrow toward the suction gun SG.
- the operator moves the leading end portion of the suction gun SG forward to cause the yarns Y to make contact with the circumferential surface of the separation roller 74 (see FIG. 11(e) and FIG. 11(f) ).
- the separation roller 74 is passively rotated by the friction force between the roller and the running yarns Y.
- the intervals in the left-right direction of the yarns Y in contact with the separation roller 74 are widened to be substantially as wide as the intervals in the left-right direction of the yarns Y regulated by the regulatory guide 8 (see FIG. 11(f) ).
- yarn paths that are aligned in the left-right direction and are substantially in parallel to one another are formed.
- the operator makes an input for starting the operation of the yarn threading mechanism 21 to the input unit of the controller 6.
- the controller 6 controls the sections of the yarn threading mechanism 21. The following will describe only the operation of the yarn threading mechanism 21 in the winding unit 5A.
- the controller 6 controls the operation of the air cylinder 56 to move the piston rod 63 of the air cylinder 56 from the extended position (see FIG. 10(b) ) to the contracted position (see FIG. 12(b) ).
- the pin 52 moves forward as a result, the swing arm 43 and the guide rail 42 are passively swung as the guide hole 51 of the swing arm 43 follows the pin 52 (see FIG. 12 (a) ). Due to this, the front end portion of the support arm 41 and the holding unit 22 follow the guide rail 42 and are swung rightward (see FIG. 12(a) ).
- the holding unit 22 moves from the holding unit retracted position to the vicinity of a capturing position (described later) where the yarns YA can be captured.
- the holding unit 22 moves from the holding unit retracted position to the capture preparation position (see FIG. 12(a) ) where the operator causes the holding unit 22 to capture the yarns YA.
- the capture preparation position is a position that is at least forward of the capturing position.
- the capture preparation position of the holding unit 22 is immediately above a left portion of the separation roller 74 and immediately in front of the yarns YA.
- the controller 6 temporarily stops the operation of the yarn threading mechanism 21.
- the controller 6 controls the electromagnetic valve EV2 (see FIG. 6(b) ) to discharge compressed air from both the piston chamber 66F and the piston chamber 66R of the air cylinder 57.
- the swing arm 43 is provided with a guide hole 51.
- the width of the guide hole 51 is very slightly larger than the outer diameter of the pin 52, except at the front end portion.
- the front end portion of the guide hole 51 has a play 53.
- the pin 52 is inserted into the front end portion of the guide hole 51 (i.e., when the piston rod 63 is at the contracted position)
- the pin 52 is loosely fitted with the play 53. Therefore, the operator can manually swing the swing arm 43 in the left-right direction by a hand (see FIGs. 13(a) and 13(b) ).
- the operator can move the holding unit 22 (and the movable body 99) in the front-rear direction when the air cylinder 57 is in a non-actuated state.
- the operator moves the comb guide 31 by holding the grip 37 by a hand.
- the holding unit 22 can be moved rearward.
- the operator manually moves the holding unit 22 from the capture preparation position to the capturing position, and causes the holding unit 22 to capture the yarns YA (see FIG. 13(c) ).
- the holding unit 22 holds the yarns YA to be separated from one another in the left-right direction, for example.
- the operator After causing the holding unit 22 to capture the yarns YA, the operator makes an input to the input unit of the controller 6 to continue the yarn threading.
- the controller 6 continues the yarn threading in accordance with the input signal.
- the controller 6 controls the air cylinder 57 to move the movable body 99 from the front end position to the rear end position.
- the controller 6 puts the air cylinder 57 in the actuated state.
- the controller 6 controls the solenoid valve EV2 to supply compressed air to the piston chamber 66F.
- the piston 67 is pushed rearward by the compressed air in the piston chamber 66F, and a predetermined force is applied to the piston 67 and the piston rod 68 (see a force F6 described in FIG. 14 (b) for details).
- the magnitude of the force F6 is required to be at least twice greater than the magnitude of the force F4.
- the controller 6 may return the second godet roller 4 to the roller rear position before controlling the solenoid valve EV2 as described above. Alternatively, the controller 6 may move the second godet roller 4 to the roller rear position after the yarn threading to the fulcrum guides 20 is completed.
- the controller 6 controls the air cylinder 56 to move the piston rod 63 from the contracted position to the extended position (see FIG. 16(b) ). Consequently, the pin 52 is moved rearward, and this causes the swing arm 43 to swing leftward. Due to this, the inclination angle of the guide rail 42 is changed relative to the front-rear direction, and the inclination angle of the holding unit 22 is also changed (see FIG. 16(a) ).
- the guide rail 42 extends obliquely forward and leftward from a position in the vicinity of the fulcrum guide 20 that is the rearmost fulcrum guide of the winding unit 5A, toward a position in the vicinity of the frontmost fulcrum guide 20.
- the holding unit 22 is at the yarn threading start position of the present invention.
- the yarn threading start position is rearward of the capturing position.
- the controller 6 controls the air cylinder 57 to move the movable body 99 from the rear end position to the front end position (see FIG. 17(c) ).
- the front end portion of the support arm 41 is moved forward along the cylinder main body 66, and the front end portion of the support arm 41 is moved obliquely forward and leftward along the guide rail 42 (see FIG. 17 (a) and FIG. 18 ) .
- the yarns YA retained in the respective retaining grooves 35 of the holding unit 22 are threaded to the corresponding fulcrum guides 20, respectively (see FIG. 18 ).
- the holding unit 22 moves to the yarn threading completion position that is at least forward of the yarn threading start position (see the full lines in FIG.
- the yarn threading to the fulcrum guides 20 of the winding unit 5B is similarly done.
- controller 6 controls the sections of the paired winding units 5 to perform, for example, the yarn threading to the bobbins B. (Details are omitted.) As a result, it becomes possible to start winding of the yarns Y onto the respective bobbins B.
- the front-rear driving mechanism 45 (adjustment mechanism) of the present embodiment utilizes the principle of movable pulley. Based on the principle, while the first distance D1 is increased, the force required to be applied to the holding unit 22 is decreased. As a result, the holding unit 22 provided in the yarn threading mechanism 21 can be positionally adjusted with a small force.
- the yarn threading mechanism 21 is configured to allow manual adjustment of the position in the front-rear direction of the holding unit 22 between the capture preparation position and the capturing position when the state of the air cylinder 57 is in the non-actuated state.
- the yarn threading mechanism 21 is configured to move the holding unit 22 from the capturing position to the yarn threading start position, and further move the same to the yarn threading completion position, thereby enabling the yarns Y held by the holding unit 22 to be threaded to the fulcrum guides 20.
- the air cylinder 57 becomes in the non-actuated state as a result of the discharge of compressed air from both the piston chamber 66F and the piston chamber 66R. That is to say, for example, it is possible to form a front-rear driving mechanism 45 (drive mechanism) by utilizing an air cylinder which is typically inexpensive as compared to a fluid pressure cylinder such as a motor-driven cylinder and a hydraulic cylinder. Therefore, it is possible to reduce the component cost of the spun yarn take-up machine 1.
- first pulley 94 and the second pulley 95 are rotatably supported by the base member 91.
- the endless belt 98 is wound onto the first pulley 94 and the second pulley 95.
- the first pulley 94, the second pulley 95, the endless belt 98, and the movable body 99 can be arranged so that they fit within an area that is approximately the same size as a range in which the base member 91 extends in the front-rear direction.
- the moving distance in the front-rear direction of the base member 91 is equal to the moving distance (extension-and-contraction distance) in the front-rear direction of the piston rod 68. This suppresses the traveling range of the transmission mechanism 83 to be short in the front-rear direction. Therefore, increase in size of the spun yarn take-up machine 1 in the front-rear direction can be avoided.
- the rotation axis center of the third pulley 96 is positioned at a different location from the rotation axis centers of the first pulley 94 and the second pulley 95 in the up-down direction. Therefore, the position in the up-down direction of the third pulley 96 can be set freely to some degree. Therefore, the positions in the up-down direction of the pinion 82 and the rack 81 can be set freely to some degree. On this account, it is possible to easily avoid an interference between the transmission mechanism 83 and the rack 81.
- the pitch circle diameter of the third pulley 96 is substantially equal to the pitch circle diameter of the pinion 82. This makes it easy to achieve both the reduction of the force required to manually move the holding unit 22 and the suppression of increase in force required to move the holding unit 22 by the air cylinder 57.
- the third pulley 96 is arranged at substantially the same position as the second pulley 95 in the front-rear direction. Therefore, it is possible to avoid the transmission mechanism 83 from being upsized in the front-rear direction due to the third pulley 96.
- the transmission mechanism 83 includes the fourth pulley 97.
- the endless belt 98 By arranging the endless belt 98 to overlap at least partially with the air cylinder 57 in the left-right direction, it is possible to suppress the enlargement of the spun yarn take-up machine 1 in the left-right direction.
- the endless belt 98 may interfere with the air cylinder 57.
- the shape of the endless belt 98 can be freely set to some extent by the fourth pulley 97. This suppresses the enlargement of the spun yarn take-up machine 1 in the left-right direction and enables easy avoidance of interference between the air cylinder 57 and the endless belt 98.
- the fourth pulley 97 is positioned between the first pulley 94 and the second pulley 95 in the front-rear direction.
- the fourth pulley 97 is provided between (i) the first pulley 94 and the second pulley 95 and (ii) the third pulley 96 in the up-down direction. Therefore, it is possible to avoid the transmission mechanism 83 from being upsized in the front-rear direction and/or the up-down direction due to the fourth pulley 97.
- the guide rail 92 is disposed to overlap at least partially with the rack 81 in the left-right direction. Therefore, it is possible to suppress the yarn threading mechanism 21 from being upsized in the left-right direction by the guide rail 92.
- the yarn threading mechanism 21 includes the rack 81 and the pinion 82.
- a typical rack-and-pinion mechanism with a simple structure is used in the yarn threading mechanism 21. Therefore, it is possible to suppress the structural complication of the yarn threading mechanism 21.
- a transmission mechanism 103 may be provided.
- an endless belt 98A may be wound onto the first pulley 94 and the second pulley 95.
- the pinion 82 may be provided on the same axis as the second pulley 95, and the rack 81 may be provided in accordance with the position of the pinion 82.
- the rack 81 may be required to be positionally different from the guide rail 92 in the left-right direction.
- the transmission mechanism 83, etc. includes the first pulley 94 and the second pulley 95.
- a transmission mechanism 104 may be provided.
- the transmission mechanism 104 may not include the first pulley 94 and the second pulley 95.
- the transmission mechanism 104 may include, for example, a rack 81, a pinion 82M, and a rack 113.
- the pitch circle diameter of the pinion 82M may be different from the pitch circle diameter of the pinion 82.
- the pinion 82M may be rotatably attached to a rod end 69A.
- the rack 113 may be provided to be opposite to the rack 81 over the pinion 82M in the up-down direction and extend in the front-rear direction, for example.
- a movable body 99A may be provided in place of the movable body 99.
- the movable body 99A may be fixed to a front end portion of the rack 113. In this arrangement, however, the relative positions of the rear end of the rack 113 and the movable body 99A remain the same in the front-rear direction. On this account, after the movable body 99A is moved to the rear end position, the rear end portion of the rack 113 may protrude rearward as compared to the rack 81. Therefore, in this modification, the installation area of the spun yarn take-up machine 1 needs to be long in the front-rear direction.
- the front-rear driving mechanism 45 includes the air cylinder 57.
- the disclosure is not limited to this.
- a known magnet-type rodless cylinder may be provided, for example.
- a fluid pressure cylinder (e.g., a hydraulic cylinder) driven by fluid different from compressed air may be provided. Also in this case, the state of the fluid pressure cylinder becomes the non-actuated state as the fluid is discharged from piston chambers (not illustrated) provided on the both sides in the front-rear direction of the cylinder main body (not illustrated) of the fluid pressure cylinder.
- an electric driving source such as a known stepping motor may be provided.
- the holding unit 22 can be manually moved.
- a stator (not illustrated) of the motor is equivalent to the fixed portion of the present invention.
- a rotor and a rotation shaft (not illustrated) of the motor are equivalent to the movable portion of the present invention.
- the installation location of the motor may not be fixed.
- the rotational shaft of the motor may be connected to the pinion 82.
- the motor may be movable with the pinion 82 in a parallel manner relative to the rack 81.
- the transmission mechanism 83, etc. includes the pulleys and the endless belt 98.
- the disclosure is not limited to this.
- known sprockets may be provided as the first to fourth rotated members of the present invention.
- a known chain (not illustrated) may be provided in place of the endless belt 98.
- the yarn threading mechanism 21 moves the holding unit 22 from the capturing position to the yarn threading start position by the drive unit 23 and further moves the holding unit 22 to the yarn threading completion position.
- the disclosure is not limited to this.
- the yarn threading mechanism 21 may be arranged so that the series of movement steps is partially performed by the operator.
- the play 53 formed at the front end portion of the guide hole 51 contributes to the position adjustment of the holding unit 22.
- the disclosure is not limited to this.
- the comb guide 31 may be swingable relative to the above-described interposed member 32.
- the comb guide 31 may be connected to the support arm 41 through an unillustrated spring (e.g., a compression coil spring, a tension coil spring, and/or a torsion coil spring).
- the air cylinder 56 is arranged to swing the guide rail 42.
- the disclosure is not limited to this.
- a mechanism configured to horizontally move the guide rail 42 may be provided.
- the guide rail 42 is linear in shape and the position of the guide rail 42 is changed according to an object.
- a guide rail (not illustrated) that does not need to be moved may be provided to extend along the track of movement of the paired holding unit 22.
- the fulcrum guides 20 are movable between the distanced positions and the gathered positions.
- the fulcrum guides 20 may be immovable. In this case, however, the drive unit 23 may be upsized in the front-rear direction.
- the holding unit 22 is moved from the holding unit retracted position to the capturing position.
- the disclosure is not limited to this. As long as the holding unit 22 is not obstructive, the holding unit 22 may be provided at the capture preparation position from the beginning.
- the yarn threading mechanism 21 includes the yarn interval increaser 24.
- the yarn threading mechanism 21 may not include the yarn interval increaser 24.
- An arrangement by which the compressed air is discharged from both of the piston chambers 66F and 66R is not limited to the arrangement shown in FIG. 6(b) .
- two three-way electromagnetic valves (not illustrated) may be provided in place of the electromagnetic valve EV2, and a path for supplying and discharging compressed air may be suitably provided to discharge the compressed air from both of the piston chambers 66F and 66R.
- the cylinder main body 66 of the air cylinder 57 is fixed to the supporting member 26.
- a swing shaft (not illustrated) may be provided at a rear end portion of the cylinder main body 66 to extend in the up-down direction, and the cylinder main body 66 may be swingable about the swing shaft.
- the guide rail 42 and the cylinder main body 66 swing together.
- the support arm 41 may be fixed to the movable body 99.
- the yarn threading mechanism 21 is arranged to thread the yarns Y to the fulcrum guides 20.
- the disclosure is not limited to this.
- a yarn threading mechanism may be provided to thread yarns Y to these yarn guides.
- spun yarn take-up machine 1 includes the paired winding units 5 (winding units 5A and 5B), the disclosure is not limited to this arrangement.
- the spun yarn take-up machine 1 may include, for example, only the winding unit 5A among the winding units 5A and 5B.
- the front-rear direction is equivalent to the first direction of the present invention
- the up-down direction is equivalent to the second direction of the present invention
- the left-right direction is equivalent to the third direction of the present invention.
- the first direction may be tilted relative to the front-rear direction.
- the second direction may be tilted relative to the up-down direction.
- the third direction may be tilted relative to the left-right direction.
- the present invention can be applied to various yarn winders each of which is configured to wind yarns Y.
Landscapes
- Engineering & Computer Science (AREA)
- Textile Engineering (AREA)
- Spinning Or Twisting Of Yarns (AREA)
- Guides For Winding Or Rewinding, Or Guides For Filamentary Materials (AREA)
- Yarns And Mechanical Finishing Of Yarns Or Ropes (AREA)
- Replacing, Conveying, And Pick-Finding For Filamentary Materials (AREA)
Applications Claiming Priority (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| JP2023049674A JP2024138941A (ja) | 2023-03-27 | 2023-03-27 | 糸巻取機 |
Publications (1)
| Publication Number | Publication Date |
|---|---|
| EP4438538A1 true EP4438538A1 (fr) | 2024-10-02 |
Family
ID=89843376
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| EP24155728.9A Pending EP4438538A1 (fr) | 2023-03-27 | 2024-02-05 | Enrouleur de fil |
Country Status (3)
| Country | Link |
|---|---|
| EP (1) | EP4438538A1 (fr) |
| JP (1) | JP2024138941A (fr) |
| CN (1) | CN118701858A (fr) |
Citations (4)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JP2012021240A (ja) | 2010-07-13 | 2012-02-02 | Tmt Machinery Inc | 紡糸巻取装置への糸掛け方法、紡糸巻取装置、及びサクションガン |
| JP2017114573A (ja) | 2015-12-21 | 2017-06-29 | Tmtマシナリー株式会社 | 糸巻取機、糸掛け部材、及び、糸巻取機の糸掛け方法 |
| EP3712097A1 (fr) * | 2019-03-18 | 2020-09-23 | TMT Machinery, Inc. | Machine textile et procédé d'enseignement |
| EP4215469A2 (fr) * | 2021-12-21 | 2023-07-26 | TMT Machinery, Inc. | Enrouleur de fil |
-
2023
- 2023-03-27 JP JP2023049674A patent/JP2024138941A/ja active Pending
-
2024
- 2024-01-21 CN CN202410086134.3A patent/CN118701858A/zh active Pending
- 2024-02-05 EP EP24155728.9A patent/EP4438538A1/fr active Pending
Patent Citations (4)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JP2012021240A (ja) | 2010-07-13 | 2012-02-02 | Tmt Machinery Inc | 紡糸巻取装置への糸掛け方法、紡糸巻取装置、及びサクションガン |
| JP2017114573A (ja) | 2015-12-21 | 2017-06-29 | Tmtマシナリー株式会社 | 糸巻取機、糸掛け部材、及び、糸巻取機の糸掛け方法 |
| EP3712097A1 (fr) * | 2019-03-18 | 2020-09-23 | TMT Machinery, Inc. | Machine textile et procédé d'enseignement |
| EP4215469A2 (fr) * | 2021-12-21 | 2023-07-26 | TMT Machinery, Inc. | Enrouleur de fil |
Also Published As
| Publication number | Publication date |
|---|---|
| CN118701858A (zh) | 2024-09-27 |
| JP2024138941A (ja) | 2024-10-09 |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| JP6211379B2 (ja) | 紡糸巻取機 | |
| CN100553952C (zh) | 绕丝设备 | |
| EP4215469B1 (fr) | Enrouleur de fil | |
| JP6393206B2 (ja) | 糸巻取機 | |
| EP3357847B1 (fr) | Bobineur de fil, appareil de rattrapage de fil fin et procédé d'enfilage de fil dans un bobineur de fil | |
| EP3184475B1 (fr) | Dispositif de bobinage de fil, élément d'enfilage de fil et procédé d'enfilage des fils dans le dispositif de bobinage de fil | |
| EP2623300A1 (fr) | Dispositif d'enroulement filamentaire | |
| CN102951496B (zh) | 用于制造交叉卷绕筒子的纺织机械的纱线捻接装置 | |
| EP2676912A2 (fr) | Enrouleur récepteur | |
| ITMI951657A1 (it) | Dispositivo di servizio per una macchina tessile producente bobine incrociate | |
| JP2941798B2 (ja) | 制御可能なよこ糸給糸把持装置及び織機特にグリッパ織機で製織するときのよこ糸屑を最小にするための装置 | |
| CN116056994A (zh) | 用于抽出并卷绕丝线的设备 | |
| EP1457446B9 (fr) | Dispositif de réglage de tension et d'élimination des relâchements de fil pour un dispositif de bobinage | |
| CN1656003A (zh) | 用于将连续送进的线在一个筒管上卷绕成一个线筒的方法及卷绕机 | |
| US3717311A (en) | Apparatus for packaging linear material | |
| JPH02242942A (ja) | 走行糸の張力を制御する装置 | |
| CN1819963A (zh) | 一种绕线机 | |
| JP2024138941A (ja) | 糸巻取機 | |
| US20020026698A1 (en) | Sample warper with detector for yarn on yarn guide | |
| CN109626108B (zh) | 纱线卷绕机 | |
| EP4357284B1 (fr) | Dispositif de libération de noeud de paquet de fil, dispositif de traitement de jonction de fil et dispositif d'alimentation en fil | |
| EP4242155A1 (fr) | Machine de bobinage de fil | |
| EP1199391B1 (fr) | Ourdissoir d'échantillonage; méthode d'ourdissage et ensemble de fils ourdis | |
| EP4624403A1 (fr) | Appareil de bobinage de fil | |
| EP4624401A1 (fr) | Appareil de bobinage de fil |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| PUAI | Public reference made under article 153(3) epc to a published international application that has entered the european phase |
Free format text: ORIGINAL CODE: 0009012 |
|
| STAA | Information on the status of an ep patent application or granted ep patent |
Free format text: STATUS: THE APPLICATION HAS BEEN PUBLISHED |
|
| AK | Designated contracting states |
Kind code of ref document: A1 Designated state(s): AL AT BE BG CH CY CZ DE DK EE ES FI FR GB GR HR HU IE IS IT LI LT LU LV MC ME MK MT NL NO PL PT RO RS SE SI SK SM TR |
|
| STAA | Information on the status of an ep patent application or granted ep patent |
Free format text: STATUS: REQUEST FOR EXAMINATION WAS MADE |
|
| 17P | Request for examination filed |
Effective date: 20241028 |
|
| RBV | Designated contracting states (corrected) |
Designated state(s): AL AT BE BG CH CY CZ DE DK EE ES FI FR GB GR HR HU IE IS IT LI LT LU LV MC ME MK MT NL NO PL PT RO RS SE SI SK SM TR |
|
| GRAP | Despatch of communication of intention to grant a patent |
Free format text: ORIGINAL CODE: EPIDOSNIGR1 |
|
| STAA | Information on the status of an ep patent application or granted ep patent |
Free format text: STATUS: GRANT OF PATENT IS INTENDED |
|
| RIC1 | Information provided on ipc code assigned before grant |
Ipc: B65H 57/00 20060101AFI20260324BHEP Ipc: B65H 57/16 20060101ALI20260324BHEP Ipc: B65H 57/28 20060101ALI20260324BHEP |
|
| INTG | Intention to grant announced |
Effective date: 20260407 |
|
| RIN1 | Information on inventor provided before grant (corrected) |
Inventor name: MATSUI, TAKANORI Inventor name: ARAKI, SHUMPEI |