EP4553033A1 - Dispositif de fermeture pour fermer un récipient avec une bouchon et procédé de surveillance d'un dispositif de fermeture - Google Patents
Dispositif de fermeture pour fermer un récipient avec une bouchon et procédé de surveillance d'un dispositif de fermeture Download PDFInfo
- Publication number
- EP4553033A1 EP4553033A1 EP24212068.1A EP24212068A EP4553033A1 EP 4553033 A1 EP4553033 A1 EP 4553033A1 EP 24212068 A EP24212068 A EP 24212068A EP 4553033 A1 EP4553033 A1 EP 4553033A1
- Authority
- EP
- European Patent Office
- Prior art keywords
- closing device
- gripping mechanism
- container
- closing
- gripping
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Pending
Links
Images



Classifications
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B67—OPENING, CLOSING OR CLEANING BOTTLES, JARS OR SIMILAR CONTAINERS; LIQUID HANDLING
- B67B—APPLYING CLOSURE MEMBERS TO BOTTLES JARS, OR SIMILAR CONTAINERS; OPENING CLOSED CONTAINERS
- B67B3/00—Closing bottles, jars or similar containers by applying caps
- B67B3/20—Closing bottles, jars or similar containers by applying caps by applying and rotating preformed threaded caps
- B67B3/2013—Closing bottles, jars or similar containers by applying caps by applying and rotating preformed threaded caps by carousel-type capping machines
- B67B3/2033—Closing bottles, jars or similar containers by applying caps by applying and rotating preformed threaded caps by carousel-type capping machines comprising carousel co-rotating capping heads
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B67—OPENING, CLOSING OR CLEANING BOTTLES, JARS OR SIMILAR CONTAINERS; LIQUID HANDLING
- B67B—APPLYING CLOSURE MEMBERS TO BOTTLES JARS, OR SIMILAR CONTAINERS; OPENING CLOSED CONTAINERS
- B67B3/00—Closing bottles, jars or similar containers by applying caps
- B67B3/26—Applications of control, warning, or safety devices in capping machinery
- B67B3/268—Applications of control, warning, or safety devices in capping machinery devices for avoiding damage to the closing machine
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B67—OPENING, CLOSING OR CLEANING BOTTLES, JARS OR SIMILAR CONTAINERS; LIQUID HANDLING
- B67B—APPLYING CLOSURE MEMBERS TO BOTTLES JARS, OR SIMILAR CONTAINERS; OPENING CLOSED CONTAINERS
- B67B3/00—Closing bottles, jars or similar containers by applying caps
- B67B3/20—Closing bottles, jars or similar containers by applying caps by applying and rotating preformed threaded caps
- B67B3/2013—Closing bottles, jars or similar containers by applying caps by applying and rotating preformed threaded caps by carousel-type capping machines
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B67—OPENING, CLOSING OR CLEANING BOTTLES, JARS OR SIMILAR CONTAINERS; LIQUID HANDLING
- B67B—APPLYING CLOSURE MEMBERS TO BOTTLES JARS, OR SIMILAR CONTAINERS; OPENING CLOSED CONTAINERS
- B67B3/00—Closing bottles, jars or similar containers by applying caps
- B67B3/20—Closing bottles, jars or similar containers by applying caps by applying and rotating preformed threaded caps
- B67B3/204—Linear-type capping machines
- B67B3/2053—Linear-type capping machines comprising capping heads
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B67—OPENING, CLOSING OR CLEANING BOTTLES, JARS OR SIMILAR CONTAINERS; LIQUID HANDLING
- B67B—APPLYING CLOSURE MEMBERS TO BOTTLES JARS, OR SIMILAR CONTAINERS; OPENING CLOSED CONTAINERS
- B67B3/00—Closing bottles, jars or similar containers by applying caps
- B67B3/20—Closing bottles, jars or similar containers by applying caps by applying and rotating preformed threaded caps
- B67B3/2066—Details of capping heads
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B67—OPENING, CLOSING OR CLEANING BOTTLES, JARS OR SIMILAR CONTAINERS; LIQUID HANDLING
- B67B—APPLYING CLOSURE MEMBERS TO BOTTLES JARS, OR SIMILAR CONTAINERS; OPENING CLOSED CONTAINERS
- B67B3/00—Closing bottles, jars or similar containers by applying caps
- B67B3/26—Applications of control, warning, or safety devices in capping machinery
- B67B3/262—Devices for controlling the caps
- B67B3/264—Devices for controlling the caps positioning of the caps
Definitions
- the present invention relates to a closing device for closing a container with a container closure, for example for closing a container with a push-on closure or a screw closure in a beverage filling plant, and to a method for monitoring a closing device for closing a container with a container closure, for example for closing a container with a push-on closure or a screw closure in a beverage filling plant.
- Closing devices for closing containers with a container closure are well known in the art. For example, a container closure fed via a pick wheel is gripped by the pick wheel's clamping jaws of a gripping mechanism and then held on the closing device by the gripping mechanism. The closing head of the closing device, which holds the container closure, is then positioned over the container to be closed and lowered onto it to close the container with the container closure. If a screw closure is to be applied to the container, the closing head undergoes a rotating movement in addition to the lowering movement. The combination of lowering and rotating allows the screw closure to be screwed onto the container.
- the state of the art provides systems that allow the replacement of closure-related components of the closing device, such as parts of the gripping mechanism, to enable the application of container closures of different geometries using the same closing head. Replacing these components is complex.
- the EP 0 876 991 B1 shows a device for screwing a cap onto a container neck, which has gripping means pivotable about horizontal axes and provided with clamping jaws for clamping the cap.
- gripping means pivotable about horizontal axes and provided with clamping jaws for clamping the cap.
- a similar construction is shown by a screwing and rolling head for attaching threaded caps, which is shown in EP 1 908 725 B1 is known.
- the US 5 851 042 A shows a clamping bushing for gripping container lids, which can be quickly exchanged using a locking pin on a closure gripping system.
- the segments of the clamping bushing are bent inward by a pressure cylinder to enable gripping of the container lid.
- the gripping mechanism of a closure device can be actuated by an actuating unit.
- the gripping mechanism can be preloaded into a certain position and moved into another position, such as an open position, by the actuating unit.
- a closing device for closing a container with a container closure for example for closing a container with a push-on closure or a screw closure, in a beverage filling system with the features of claim 1.
- a closing device for closing a container with a container closure for example for closing a container with a push-on closure or a screw closure in a beverage filling plant, comprising a gripping mechanism for gripping the container closure with at least one gripping arm pivotable about a bearing and an actuating unit for actuating the gripping mechanism.
- the closing device further comprises a detection unit for detecting a stroke of a lifting element of the actuating unit acting on the gripping mechanism.
- various parameters can be determined, which in turn allow conclusions to be drawn, for example, about the actual switching times of the gripping mechanism. This can, in turn, be used to achieve higher system performance of a container closing device that includes the closing device.
- the measured stroke can also be used to obtain information regarding the condition monitoring of the closing device, particularly with regard to the parts of the gripping mechanism.
- parameters of the closing device such as the closing time and the opening time, can be automatically determined depending on the type of container closure currently being processed.
- Detecting the stroke also allows conclusions to be drawn about the current wear of the closing device, especially when the currently measured stroke, especially the stroke at the time of closing and/or opening of the gripping mechanism, is compared with values recorded initially, for example, during or shortly after setup. Accordingly, wear limits can be determined to plan or initiate the replacement of wear-prone parts of the closing device.
- the detection of the stroke can be used to detect system errors in the programming, mechanics and/or pneumatics of the closing device and/or the container closing device comprising it.
- the recorded stroke values can also be used to determine further data for the digitalization of the closing process.
- the closing device can optionally comprise an evaluation unit for determining at least one of the above parameters.
- the container closing device can also comprise such an evaluation unit.
- a central system control system for a container treatment system can be provided.
- the detection unit can comprise at least one sensor, for example, a non-contact sensor.
- a non-contact sensor can be, for example, a displacement sensor, for example, in the form of a Hall sensor.
- the actuating unit can be designed as an actuating cylinder.
- the lifting element can be a cylinder piston of the actuating cylinder.
- a reference element can be arranged on the lifting element, optionally extending perpendicular to the stroke direction of the lifting element.
- the reference element can serve as a reference for the sensor used.
- a displacement sensor or distance sensor can measure the distance between itself and the reference element, with the stroke being based on or corresponding to the measured distance or a change in the distance.
- the closing device may further comprise a control unit which is configured to determine at least one state variable of the gripping mechanism based on at least one signal of the detection unit.
- the state variable can be indicative of wear of the gripping mechanism or correspond to wear of the gripping mechanism.
- the control unit can be configured to use the determined state variable to draw conclusions about the condition and/or existing wear of the gripping mechanism and, in turn, to use this state variable as a data basis, for example, to output a warning and/or control signals in response to the processing of the determined state variable.
- control unit can be configured to initiate an adjustment of at least one operating parameter of the closing device based on at least one signal of the detection unit and/or at least one determined state variable, wherein optionally at least one operating parameter is a control point and/or switching time for controlling the lifting element.
- the proposed closing device can be individually adapted. This is particularly advantageous when a plurality of gripping mechanisms or a plurality of closing devices are provided on a container closing device.
- control unit can be configured to output a message, for example a warning message, an error message and/or an information message, for example a status message, based on at least one signal from the detection unit and/or at least one determined state variable.
- the gripping mechanism may comprise a control element displaceable in the direction of the stroke of the lifting element, which control element is coupled to the at least one gripping arm for controlling the position of the at least one gripping arm.
- the closing device may comprise a lifting unit for raising and lowering the gripping mechanism in a displacement direction.
- the lifting unit may comprise a fastening part for fastening to a transport unit of a container treatment device and a relative to the fastening part in a displacement direction displaceable moving part, wherein the moving part is connected to the gripping mechanism.
- the moving part can comprise the actuating unit.
- a particularly simple structure can be achieved if the displacement direction and the lifting direction of the lifting element are oriented parallel, whereby a central longitudinal axis of the moving part and a central axis of the lifting element can be concentric to each other.
- a method for monitoring a closing device for closing a container with a container closure for example for closing a container with a push-on closure or a screw closure in a beverage filling plant, which comprises a gripping mechanism for gripping a container closure with at least one gripping arm pivotable about a bearing and an actuating unit for actuating the gripping mechanism, is proposed.
- a stroke of a lifting element of the actuating unit acting on the gripping mechanism is detected.
- the method allows the advantages and effects described with regard to the closing device to be achieved in an analogous manner. A repetitive description of these is omitted to avoid redundancies.
- At least one state variable of the gripping mechanism can be determined based on the detected stroke.
- the state variable can be indicative of wear of the gripping mechanism or correspond to wear of the gripping mechanism.
- an adjustment of at least one operating parameter the closing device based on the determined stroke and/or at least one determined state variable, an adjustment of at least one operating parameter the closing device, wherein optionally at least one operating parameter is a control point and/or switching time for controlling the lifting element.
- a message for example a warning message, an error message and/or an information message, for example a status message, can be output based on the determined stroke and/or at least one determined state variable.
- Figure 1 is a schematic perspective side view of a container closing device 100 designed in a rotary type for closing containers with one container closure each.
- the container closing device 100 comprises a frame 101 on which a treatment carousel 102 is arranged to rotate about a rotation axis 103.
- the treatment carousel 102 comprises a plurality of closing devices 1 for closing a container with a container closure, which are arranged at equal distances from one another on the circumference of the treatment carousel 102.
- the container closure device 100 comprises a sealing section 104, which serves as a separation between a treatment space designed as a clean room below the sealing section 104 and a grey room above the sealing section 104.
- Figure 2 shows schematically a perspective side view of a closing device 1 of the container closing device 100 from Figure 1 .
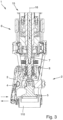
- Figure 3 shows a sectional view through a lower part 17 of the closing device 1.
- the closing device 1 is designed and configured for closing a container with a container closure 110, in this case for closing a container with a screw cap 110 in a beverage filling system. It comprises a gripping mechanism 2 for gripping the container closure 110, in this case with three gripping arms 3, each pivotable about a bearing 4.
- the actuating unit 6 is designed and configured to actuate the gripping arms 3 of the gripping mechanism 2.
- the actuating unit 6 controls pivoting of the gripping arms 3.
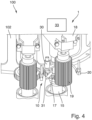
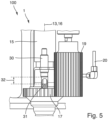
- the closing device 1 further comprises a detection unit 10 for detecting a stroke of a lifting element 7 acting on the gripping mechanism 2 (see Figure 3 ) of the actuating unit 6, as described below with regard to the Figures 4 and 5 explained in more detail.
- the gripping mechanism 2 further comprises a control element 8 or coupling element which is displaceable in the direction of the stroke of the lifting element 7 and which is coupled to the gripping arms 3 with a control element for controlling the position of the gripping arms 3.
- the gripping arms 3 are each pivotably mounted around the bearing 4. They are coupled to the lifting element 7 via the control element 8 in such a way that a lowering of the lifting element 7, i.e. a movement of the lifting element 7 in the direction of the axis required for receiving the container closure 110 provided space between the gripping arms 3, as indicated by the continuous arrows in Figure 3 indicated, an opening of the gripping mechanism 2, i.e. a pivoting of the gripping arms 3 into an open position, requires.
- the actuating unit 6 is designed as an actuating cylinder and the lifting element 7 is a cylinder piston.
- the closing device 1 comprises a lifting unit 12 for raising and lowering the gripping mechanism 2 in a displacement direction 13.
- the lifting unit 12 comprises a fastening part 14 for fastening to the treatment carousel 102, which represents a transport unit. It further comprises a moving part 15 that can be moved relative to the fastening part 14 in the displacement direction 13.
- the moving part 15 is connected to the gripping mechanism 2 or comprises it and also comprises the actuating unit 6.
- the position of the moving part 15 relative to the fastening part 14 is predetermined by a guide 106 on the frame 101, which is designed here as a slotted guide and on which a guide roller 21 arranged on the moving part 15 is guided.
- the displacement direction 13 (see Figure 2 ) of the stroke direction 16 of the lifting element 7.
- the stroke direction 16 and the displacement direction 13 are thus oriented parallel.
- the displacement direction 13, which represents a central longitudinal axis of the moving part 15, and the stroke direction 16, which represents a central axis of the lifting element 7, are concentric with each other.
- the container closure 110 is held radially by the gripping arms 3. It rests on a stop 5 at its front end, via which the head pressure required to apply the container closure 110 to a container can be applied.
- the closing device 1 is designed for applying a screw cap. Accordingly, a lower part 17 of the moving part 15 is designed to be rotatable about the displacement direction 13. The rotational movement is determined by a motor 18, here an electric motor, which is coupled to the rotatable part 17 of the moving part 15 via a gear 19.
- the turning function is either omitted or blocked.
- the movements of the lifting element 7 and thus the movements of the gripper arms 3 are controlled via a pneumatic connection 20.
- Figure 4 shows schematically a perspective detailed view of the closing device 1.
- Figure 5 shows schematically another view of the detail from Figure 4 .
- the closing device 1 further comprises a Figure 4 schematically indicated control unit 33, which is configured to determine at least one state variable of the gripping mechanism 2 based on at least one signal from the detection unit 10.
- state variable is indicative of wear of the gripping mechanism 2.
- the control unit 33 is configured to initiate an adjustment of at least one operating parameter of the closing device 1 based on at least one signal from the detection unit 10 and/or at least one determined state variable.
- the operating parameter can be a control point and/or a switching time for controlling the lifting element.
- the control unit 33 is further configured to perform various To output messages, here warning messages, error messages and information messages, for example status messages.
- control unit 33 or its functionality can alternatively also be at least partially integrated into a central control 105 of the container treatment device 100.
- the method comprises, in a step S10, detecting the stroke of the lifting element 7 of the actuating unit 6 acting on the gripping mechanism 2.
- step S12 at least one state variable of the gripping mechanism 2 is determined based on the detected stroke.
- the state variable is indicative of wear of the gripping mechanism.
- step S14 at least one operating parameter of the closing device is adjusted based on the determined stroke and/or at least one determined state variable.
- the operating parameters are a control point and a switching time for controlling the lifting element 7.
- step S16 a check is made to determine whether a message flag should be activated based on the determined stroke and/or at least one determined state variable. Depending on the activated message flag, a message, for example a warning message, an error message, or an information message, here embodied as a status message, is output (S18).
- a message for example a warning message, an error message, or an information message, here embodied as a status message.
Landscapes
- Engineering & Computer Science (AREA)
- Mechanical Engineering (AREA)
- Sealing Of Jars (AREA)
- Filling Of Jars Or Cans And Processes For Cleaning And Sealing Jars (AREA)
Applications Claiming Priority (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| DE102023131292.8A DE102023131292A1 (de) | 2023-11-10 | 2023-11-10 | Verschließvorrichtung zum Verschließen eines Behälters mit einem Behälterverschluss und Verfahren zum Überwachen einer Verschließvorrichtung |
Publications (1)
| Publication Number | Publication Date |
|---|---|
| EP4553033A1 true EP4553033A1 (fr) | 2025-05-14 |
Family
ID=93462963
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| EP24212068.1A Pending EP4553033A1 (fr) | 2023-11-10 | 2024-11-11 | Dispositif de fermeture pour fermer un récipient avec une bouchon et procédé de surveillance d'un dispositif de fermeture |
Country Status (4)
| Country | Link |
|---|---|
| US (1) | US12583723B2 (fr) |
| EP (1) | EP4553033A1 (fr) |
| CN (1) | CN119976723A (fr) |
| DE (1) | DE102023131292A1 (fr) |
Citations (6)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| US5851042A (en) | 1997-01-09 | 1998-12-22 | Bankuty; Geza E. | Collet for gripping container caps |
| EP0876991B1 (fr) | 1997-05-06 | 2003-08-13 | AZIONARIA COSTRUZIONI MACCHINE AUTOMATICHE-A.C.M.A.-S.p.A. | Dispositif pour visser un bouchon sur le col d'un récipient |
| WO2003089360A1 (fr) * | 2002-04-22 | 2003-10-30 | Serac Group | Dispositif de vissage de bouchons |
| EP1908725B1 (fr) | 2006-10-02 | 2009-12-30 | Arol S.p.A. | Tête de vissage et de sertissage pour l'application de capsules pre-filetées |
| US20120222387A1 (en) * | 2009-09-14 | 2012-09-06 | Arol S.P.A. | Method and plant for filling bottles or containers with continuous calibration |
| WO2017182453A1 (fr) * | 2016-04-18 | 2017-10-26 | Krones Ag | Tête de dispositif de fermeture servant à fermer un contenant doté d'une fermeture |
Family Cites Families (6)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JPH11124196A (ja) * | 1997-10-22 | 1999-05-11 | Kao Corp | ねじの締付方法及び装置 |
| US20090133537A1 (en) * | 2007-11-26 | 2009-05-28 | Uglum Rick A | Bottle cap remover and assembly methods |
| EP2886508B1 (fr) * | 2013-12-20 | 2016-04-13 | CTC Analytics AG | Dispositif d'actionnement pour couvercle à vis |
| US20150360800A1 (en) * | 2014-06-11 | 2015-12-17 | Windak Inc. | System and method for securing free end of wound cable |
| DE102021127195A1 (de) * | 2021-10-20 | 2023-04-20 | Krones Aktiengesellschaft | Verschließen von Behältern mit Behälterverschlüssen |
| DE102021132348A1 (de) * | 2021-12-08 | 2023-06-15 | Krones Aktiengesellschaft | Vorrichtung zum Verschließen eines Behälters mit einem Behälterverschluss |
-
2023
- 2023-11-10 DE DE102023131292.8A patent/DE102023131292A1/de active Pending
-
2024
- 2024-11-07 CN CN202411581712.7A patent/CN119976723A/zh active Pending
- 2024-11-08 US US18/942,144 patent/US12583723B2/en active Active
- 2024-11-11 EP EP24212068.1A patent/EP4553033A1/fr active Pending
Patent Citations (6)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| US5851042A (en) | 1997-01-09 | 1998-12-22 | Bankuty; Geza E. | Collet for gripping container caps |
| EP0876991B1 (fr) | 1997-05-06 | 2003-08-13 | AZIONARIA COSTRUZIONI MACCHINE AUTOMATICHE-A.C.M.A.-S.p.A. | Dispositif pour visser un bouchon sur le col d'un récipient |
| WO2003089360A1 (fr) * | 2002-04-22 | 2003-10-30 | Serac Group | Dispositif de vissage de bouchons |
| EP1908725B1 (fr) | 2006-10-02 | 2009-12-30 | Arol S.p.A. | Tête de vissage et de sertissage pour l'application de capsules pre-filetées |
| US20120222387A1 (en) * | 2009-09-14 | 2012-09-06 | Arol S.P.A. | Method and plant for filling bottles or containers with continuous calibration |
| WO2017182453A1 (fr) * | 2016-04-18 | 2017-10-26 | Krones Ag | Tête de dispositif de fermeture servant à fermer un contenant doté d'une fermeture |
Also Published As
| Publication number | Publication date |
|---|---|
| DE102023131292A1 (de) | 2025-05-15 |
| US20250153989A1 (en) | 2025-05-15 |
| US12583723B2 (en) | 2026-03-24 |
| CN119976723A (zh) | 2025-05-13 |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| EP3702318B1 (fr) | Tête de bouchage pour fermer des récipients avec des bouchons | |
| DE102011055899B4 (de) | Verfahren und eine Vorrichtung zum Handhaben von Probenbehältern | |
| DE60207321T2 (de) | Verschlussvorrichtung und -methode | |
| EP0571980B1 (fr) | Dispositif de vissage de deux objets, en particulier de vissage d'une fermeture sur un récipient | |
| EP0611363B1 (fr) | Dispositif de changement de bobines | |
| DE60107475T2 (de) | Kapselmaschine und -Verfahren | |
| EP2338829B1 (fr) | Dispositif et procédé de fermeture de récipients à l'aide de mesures de distance | |
| EP2886508B1 (fr) | Dispositif d'actionnement pour couvercle à vis | |
| EP3871829A1 (fr) | Procédé de serrage de raccords à vis, dispositif à vis multiples | |
| EP0502822A1 (fr) | Dispositif de déplacement et de virement d'une fermeture pour récipients | |
| EP1103349A2 (fr) | Outil de pressage et méthode de commande dudit outil | |
| DE69025798T2 (de) | Mehrfarbige Flexodruckmaschine mit einer Vorrichtung zum automatischen Auf- und Abladen von Plattenzylindern | |
| EP3360703B2 (fr) | Attelage | |
| DE2442798A1 (de) | Vorrichtung fuer schraubenverbindungen | |
| EP4197962B1 (fr) | Dispositif de fermeture d'un récipient avec une fermeture de récipient | |
| EP2203377B1 (fr) | Procédé et dispositif pour fermer des contenants | |
| DE102023131292A1 (de) | Verschließvorrichtung zum Verschließen eines Behälters mit einem Behälterverschluss und Verfahren zum Überwachen einer Verschließvorrichtung | |
| DE3924792A1 (de) | Reifenmontiergeraet | |
| DE4419323A1 (de) | Verfahren und Vorrichtung zum Aufschrauben von Verschlüssen auf Behälter | |
| DE102015209378A1 (de) | Verfahren zum Betrieb eines Arbeitsgeräts einer Bohranlage, nach dem Verfahren arbeitendes Arbeitsgerät, Computerprogramm zur Implementierung des Verfahrens, Steuerungseinrichtung mit einer Implementierung des Verfahrens und Bohranlage mit einem solchen Arbeitsgerät | |
| EP0732297A2 (fr) | Elément de support | |
| EP0063279A1 (fr) | Dispositif pour raccorder des douilles d'électrode dans un four électrique | |
| EP1126346A2 (fr) | Dispositif de surveillance | |
| EP4647365A1 (fr) | Dispositif de levage et de basculement et méthode d'utilisation d'un dispositif de levage et de basculement | |
| EP2291320A1 (fr) | Dispositif et procédé de vérification de l étanchéité de capuchons de fermeture sur des corps creux utilisés dans le domaine médical |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| PUAI | Public reference made under article 153(3) epc to a published international application that has entered the european phase |
Free format text: ORIGINAL CODE: 0009012 |
|
| STAA | Information on the status of an ep patent application or granted ep patent |
Free format text: STATUS: THE APPLICATION HAS BEEN PUBLISHED |
|
| AK | Designated contracting states |
Kind code of ref document: A1 Designated state(s): AL AT BE BG CH CY CZ DE DK EE ES FI FR GB GR HR HU IE IS IT LI LT LU LV MC ME MK MT NL NO PL PT RO RS SE SI SK SM TR |
|
| STAA | Information on the status of an ep patent application or granted ep patent |
Free format text: STATUS: REQUEST FOR EXAMINATION WAS MADE |
|
| 17P | Request for examination filed |
Effective date: 20251031 |