JP2012141983A - 同時の位置決定およびマップ作成方法 - Google Patents
同時の位置決定およびマップ作成方法 Download PDFInfo
- Publication number
- JP2012141983A JP2012141983A JP2011287111A JP2011287111A JP2012141983A JP 2012141983 A JP2012141983 A JP 2012141983A JP 2011287111 A JP2011287111 A JP 2011287111A JP 2011287111 A JP2011287111 A JP 2011287111A JP 2012141983 A JP2012141983 A JP 2012141983A
- Authority
- JP
- Japan
- Prior art keywords
- range
- particles
- occupied
- calculated
- travel
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Granted
Links
Images

Classifications
-
- G—PHYSICS
- G05—CONTROLLING; REGULATING
- G05D—SYSTEMS FOR CONTROLLING OR REGULATING NON-ELECTRIC VARIABLES
- G05D1/00—Control of position, course, altitude or attitude of land, water, air or space vehicles, e.g. using automatic pilots
- G05D1/02—Control of position or course in two dimensions
- G05D1/021—Control of position or course in two dimensions specially adapted to land vehicles
- G05D1/0268—Control of position or course in two dimensions specially adapted to land vehicles using internal positioning means
- G05D1/0274—Control of position or course in two dimensions specially adapted to land vehicles using internal positioning means using mapping information stored in a memory device
-
- A—HUMAN NECESSITIES
- A47—FURNITURE; DOMESTIC ARTICLES OR APPLIANCES; COFFEE MILLS; SPICE MILLS; SUCTION CLEANERS IN GENERAL
- A47L—DOMESTIC WASHING OR CLEANING; SUCTION CLEANERS IN GENERAL
- A47L9/00—Details or accessories of suction cleaners, e.g. mechanical means for controlling the suction or for effecting pulsating action; Storing devices specially adapted to suction cleaners or parts thereof; Carrying-vehicles specially adapted for suction cleaners
- A47L9/009—Carrying-vehicles; Arrangements of trollies or wheels; Means for avoiding mechanical obstacles
-
- G—PHYSICS
- G05—CONTROLLING; REGULATING
- G05D—SYSTEMS FOR CONTROLLING OR REGULATING NON-ELECTRIC VARIABLES
- G05D1/00—Control of position, course, altitude or attitude of land, water, air or space vehicles, e.g. using automatic pilots
- G05D1/02—Control of position or course in two dimensions
- G05D1/021—Control of position or course in two dimensions specially adapted to land vehicles
- G05D1/0231—Control of position or course in two dimensions specially adapted to land vehicles using optical position detecting means
- G05D1/0238—Control of position or course in two dimensions specially adapted to land vehicles using optical position detecting means using obstacle or wall sensors
-
- A—HUMAN NECESSITIES
- A47—FURNITURE; DOMESTIC ARTICLES OR APPLIANCES; COFFEE MILLS; SPICE MILLS; SUCTION CLEANERS IN GENERAL
- A47L—DOMESTIC WASHING OR CLEANING; SUCTION CLEANERS IN GENERAL
- A47L2201/00—Robotic cleaning machines, i.e. with automatic control of the travelling movement or the cleaning operation
- A47L2201/04—Automatic control of the travelling movement; Automatic obstacle detection
Landscapes
- Engineering & Computer Science (AREA)
- Radar, Positioning & Navigation (AREA)
- Physics & Mathematics (AREA)
- Aviation & Aerospace Engineering (AREA)
- Remote Sensing (AREA)
- General Physics & Mathematics (AREA)
- Automation & Control Theory (AREA)
- Mechanical Engineering (AREA)
- Electromagnetism (AREA)
- Control Of Position, Course, Altitude, Or Attitude Of Moving Bodies (AREA)
- Electric Vacuum Cleaner (AREA)
Abstract
【解決手段】装置1が送/受光ユニットからなる障害物検出装置を備え、さらに占有された予め計算された装置の最初の位置からの多数の可能な位置および方位(パーティクル(小部分)6)が計算され、および装置1対応した走行後の次に占有される第2の位置に関し、光学ユニットの測定結果に基づき確率を考慮した所定の選択アルゴリズムに従って、予め発生されたパーティクル6の1つが装置1の新たな位置として占有される同時の位置決定およびマップ作成方法である。さらに改善するために前記パーティクル6の計算が装置1の所定の走行方向rおよび走行距離ないしは走行速度により決定される立体角αおよび間隔範囲aに関して制限される。
【選択図】図2
Description
装置が、送/受光ユニットからなる障害物検出装置を備え、
さらに、占有された、予め計算された装置の最初の位置からの、多数の可能な位置および方位(パーティクル(小部分))(これらの「位置および方位」を以下「パーティクル(小部分)」と称することとする)が計算され、および装置のそれに対応した走行後に次に占有される第2の位置に関して、光学ユニットの測定結果に基づき、確率を考慮した所定の選択アルゴリズムに従って、予め発生されたパーティクルの1つが装置の新たな位置として占有される、同時の位置決定およびマップ作成方法に関するものである。
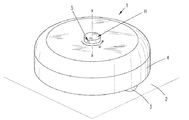
2 床
3 走行車
4 装置フード
5 センサ
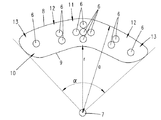
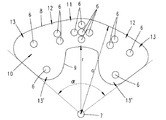
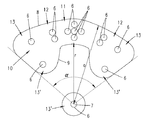
6 パーティクル(小部分)
7 パーティクル(小部分)
8 最遠線
9 最近線
10 パーティクル分散範囲
11 より高い滞留確率の範囲
12 中間の滞留確率の範囲
13 より低い滞留確率の範囲
13′ より低い滞留確率の範囲
a 間隔範囲
r 走行方向
x 回転軸線
H 障害物検出装置
α 立体角
Claims (5)
- 好ましくは電動駆動走行車(3)を有する自走式装置(1)特に自走式床集塵装置を自動位置決めするための、同時の位置決定およびマップ作成方法であって、この場合、
装置(1)が、送/受光ユニットからなる障害物検出装置(H)を備え、
さらに、占有された、予め計算された装置(1)の最初の位置からの、多数の可能な位置および方位(パーティクル(小部分)6)が計算され、および装置(1)のそれに対応した走行後に次に占有される第2の位置に関して、光学ユニットの測定結果に基づき、確率を考慮した所定の選択アルゴリズムに従って、予め発生されたパーティクル(6)の1つが装置(1)の新たな位置として占有される、同時の位置決定およびマップ作成方法において、
前記パーティクル(6)の計算が、装置(1)の所定の走行方向(r)および走行距離ないしは走行速度により決定される立体角(α)および間隔範囲(a)に関して、制限されることを特徴とする同時の位置決定およびマップ作成方法。 - 前記立体角(α)および間隔範囲(a)の内部に、さらに、より高い滞留確率の範囲(11)およびより低い滞留確率の範囲(13)が定義されること、および
より高い滞留確率の範囲(11)内に、より低い滞留確率の範囲(13)内よりも多いパーティクル(6)が計算されること、を特徴とする請求項1に記載の方法。 - 前記間隔範囲(α)に関して最遠線(8)および最近線(9)が設けられ、それらの内部においてのみパーティクル(6)が計算されることを特徴とする請求項1または2に記載の方法。
- 前記最遠線(8)および最近線(9)が、占有された装置(1)の最初の位置からの半径線であることを特徴とする請求項1ないし3のいずれかに記載の方法。
- 前記立体角の境界に隣接して、前記立体角の境界から遠い範囲内においてよりも、予め計算された装置(1)の位置に近接する範囲(13′)内においてもまた、パーティクル(6)が計算されることを特徴とする請求項1ないし4のいずれかに記載の方法。
Applications Claiming Priority (2)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| DE102011000009.7 | 2011-01-03 | ||
| DE102011000009A DE102011000009A1 (de) | 2011-01-03 | 2011-01-03 | Verfahren zur gleichzeitigen Bestimmung und Kartenbildung |
Publications (2)
| Publication Number | Publication Date |
|---|---|
| JP2012141983A true JP2012141983A (ja) | 2012-07-26 |
| JP5827891B2 JP5827891B2 (ja) | 2015-12-02 |
Family
ID=45495725
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| JP2011287111A Expired - Fee Related JP5827891B2 (ja) | 2011-01-03 | 2011-12-28 | 同時の位置決定およびマップ作成方法 |
Country Status (5)
| Country | Link |
|---|---|
| EP (1) | EP2471426B1 (ja) |
| JP (1) | JP5827891B2 (ja) |
| CN (1) | CN102608618B (ja) |
| DE (1) | DE102011000009A1 (ja) |
| ES (1) | ES2727617T3 (ja) |
Cited By (1)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JP2012155716A (ja) * | 2011-01-21 | 2012-08-16 | Vorwerk & Co Interholding Gmbh | 自走式装置の位置の決定方法 |
Families Citing this family (20)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| DE102012110387A1 (de) | 2012-10-30 | 2014-04-30 | Vorwerk & Co. Interholding Gmbh | Flächen-Reinigungsroboter |
| DE102012111149B4 (de) | 2012-11-20 | 2023-12-21 | Vorwerk & Co. Interholding Gmbh | Reinigungsgerät |
| CN103853154B (zh) | 2012-12-05 | 2018-09-18 | 德国福维克控股公司 | 可行走的清洁设备和运行这种设备的方法 |
| DE102014105460A1 (de) | 2014-04-16 | 2015-10-22 | Vorwerk & Co. Interholding Gmbh | Selbstfahrendes Bodenreinigungsgerät mit einem einem Führungsfahrzeug folgenden Folgewerkzeug |
| ES2675363T3 (es) * | 2014-06-05 | 2018-07-10 | Softbank Robotics Europe | Procedimiento de construcción de un mapa de probabilidad entre la ausencia y la presencia de obstáculos para un robot autónomo |
| DE102014110265A1 (de) | 2014-07-22 | 2016-01-28 | Vorwerk & Co. Interholding Gmbh | Verfahren zur Reinigung oder Bearbeitung eines Raumes mittels eines selbsttätig verfahrbaren Gerätes |
| DE102014111217A1 (de) | 2014-08-06 | 2016-02-11 | Vorwerk & Co. Interholding Gmbh | Bodenreinigungsgerät zur Trocken- und Feuchtreinigung sowie Verfahren zum Betrieb eines selbstfahrenden Bodenreinigungsgerätes |
| CN105469405B (zh) * | 2015-11-26 | 2018-08-03 | 清华大学 | 基于视觉测程的同时定位与地图构建方法 |
| CN107184157A (zh) * | 2017-07-26 | 2017-09-22 | 魏龙飞 | 一种具有红外检测单元的扫地机器人 |
| CN107260080A (zh) * | 2017-07-26 | 2017-10-20 | 魏龙飞 | 一种具有红外检测装置的扫地机器人 |
| CN108733043B (zh) * | 2017-09-01 | 2021-12-14 | 北京猎户星空科技有限公司 | 机器人移动控制方法和装置 |
| CN108873879B (zh) | 2017-09-25 | 2022-03-04 | 北京石头创新科技有限公司 | 自主移动机器人及其寻桩方法、控制装置和智能清洁系统 |
| CN114504276B (zh) | 2017-09-25 | 2023-11-28 | 北京石头创新科技有限公司 | 自主移动机器人及其寻桩方法和控制装置 |
| CN107958037B (zh) * | 2017-11-21 | 2020-06-26 | 中国计量大学 | 一种将虚拟地图技术和室内精确定位结合的方法 |
| CN108170137A (zh) * | 2017-12-15 | 2018-06-15 | 珊口(上海)智能科技有限公司 | 移动机器人及其控制方法和控制系统 |
| CN108247647B (zh) * | 2018-01-24 | 2021-06-22 | 速感科技(北京)有限公司 | 一种清洁机器人 |
| CN108937702B (zh) * | 2018-07-05 | 2021-05-18 | 广东宝乐机器人股份有限公司 | 一种用于机器人的边界检测方法、装置、机器人及介质 |
| CN108919300B (zh) * | 2018-07-17 | 2022-07-08 | 重庆大学 | 一种面向仓库通道场景的混合地图创建方法 |
| CN112987732A (zh) * | 2021-02-20 | 2021-06-18 | 陕西理工大学 | 基于人工势场法的多移动机器人编队避障控制方法 |
| CN113379841B (zh) * | 2021-06-21 | 2024-04-30 | 上海仙工智能科技有限公司 | 一种基于相位相关法与因子图的激光slam方法及其可读存储介质 |
Family Cites Families (5)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| DE10242257C5 (de) | 2001-09-14 | 2017-05-11 | Vorwerk & Co. Interholding Gmbh | Selbsttätig verfahrbares Bodenstaub-Aufsammelgerät, sowie Kombination eines derartigen Aufsammelgerätes und einer Basisstation |
| US20080065276A1 (en) * | 2004-05-21 | 2008-03-13 | Sorensen Research And Devlopment Trust | Remotely logging into a personal computer |
| EP1920326A4 (en) * | 2005-09-02 | 2014-01-08 | Neato Robotics Inc | ROBOT MULTIFUNCTION DEVICE |
| JP2009093308A (ja) * | 2007-10-05 | 2009-04-30 | Hitachi Industrial Equipment Systems Co Ltd | ロボットシステム |
| DE102008014912B4 (de) | 2008-03-19 | 2023-01-19 | Vorwerk & Co. Interholding Gmbh | Selbsttätig verfahrbares Bodenstaub-Aufsammelgerät |
-
2011
- 2011-01-03 DE DE102011000009A patent/DE102011000009A1/de not_active Withdrawn
- 2011-12-28 JP JP2011287111A patent/JP5827891B2/ja not_active Expired - Fee Related
-
2012
- 2012-01-02 ES ES12150001T patent/ES2727617T3/es active Active
- 2012-01-02 EP EP12150001.1A patent/EP2471426B1/de active Active
- 2012-01-04 CN CN201210069059.7A patent/CN102608618B/zh active Active
Cited By (1)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JP2012155716A (ja) * | 2011-01-21 | 2012-08-16 | Vorwerk & Co Interholding Gmbh | 自走式装置の位置の決定方法 |
Also Published As
| Publication number | Publication date |
|---|---|
| DE102011000009A1 (de) | 2012-07-05 |
| ES2727617T3 (es) | 2019-10-17 |
| EP2471426A3 (de) | 2018-02-28 |
| JP5827891B2 (ja) | 2015-12-02 |
| CN102608618B (zh) | 2016-06-08 |
| EP2471426A2 (de) | 2012-07-04 |
| CN102608618A (zh) | 2012-07-25 |
| EP2471426B1 (de) | 2019-03-27 |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| JP5827891B2 (ja) | 同時の位置決定およびマップ作成方法 | |
| JP5923311B2 (ja) | 自走式装置の位置の決定方法 | |
| CN112654470B (zh) | 机器人清洁器及其控制方法 | |
| US12001223B2 (en) | Plurality of autonomous mobile robots and controlling method for the same | |
| US11740625B2 (en) | Plurality of autonomous mobile robots and controlling method for the same | |
| AU2019262467B2 (en) | A plurality of robot cleaner and a controlling method for the same | |
| AU2019262482B2 (en) | Plurality of autonomous mobile robots and controlling method for the same | |
| US11409308B2 (en) | Robot cleaner and a controlling method for the same | |
| US11169539B2 (en) | Plurality of autonomous mobile robots and controlling method for the same | |
| US20210114220A1 (en) | A plurality of autonomous cleaners and a controlling method for the same | |
| US12004702B2 (en) | Mobile robot and method of controlling mobile robot | |
| KR102070283B1 (ko) | 청소기 및 그 제어방법 | |
| US12266128B2 (en) | Moving robot and controlling method for the moving robot | |
| EP3809939B1 (en) | Plurality of autonomous cleaner and controlling method for the same | |
| US12016519B2 (en) | Robot cleaner and method for controlling same | |
| US11832782B2 (en) | Vacuum cleaner and method for controlling same | |
| KR102535719B1 (ko) | 이동 로봇 및 이동 로봇의 제어방법 | |
| US12150609B2 (en) | Robot cleaner and method for operating same | |
| KR102179057B1 (ko) | 복수의 자율주행 청소기 | |
| KR102100474B1 (ko) | 인공지능 청소기 및 그 제어방법 | |
| KR102115193B1 (ko) | 로봇 청소기 및 그 동작방법 | |
| CN121969951A (zh) | 地面机器人以及导航方法 |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| A621 | Written request for application examination |
Free format text: JAPANESE INTERMEDIATE CODE: A621 Effective date: 20140901 |
|
| A977 | Report on retrieval |
Free format text: JAPANESE INTERMEDIATE CODE: A971007 Effective date: 20150710 |
|
| A131 | Notification of reasons for refusal |
Free format text: JAPANESE INTERMEDIATE CODE: A131 Effective date: 20150721 |
|
| A521 | Request for written amendment filed |
Free format text: JAPANESE INTERMEDIATE CODE: A523 Effective date: 20150825 |
|
| TRDD | Decision of grant or rejection written | ||
| A01 | Written decision to grant a patent or to grant a registration (utility model) |
Free format text: JAPANESE INTERMEDIATE CODE: A01 Effective date: 20150929 |
|
| A61 | First payment of annual fees (during grant procedure) |
Free format text: JAPANESE INTERMEDIATE CODE: A61 Effective date: 20151019 |
|
| R150 | Certificate of patent or registration of utility model |
Ref document number: 5827891 Country of ref document: JP Free format text: JAPANESE INTERMEDIATE CODE: R150 |
|
| R250 | Receipt of annual fees |
Free format text: JAPANESE INTERMEDIATE CODE: R250 |
|
| R250 | Receipt of annual fees |
Free format text: JAPANESE INTERMEDIATE CODE: R250 |
|
| LAPS | Cancellation because of no payment of annual fees |