JP2014111145A - バイオセンシング及び外科的処置のための能動的カニューレ - Google Patents
バイオセンシング及び外科的処置のための能動的カニューレ Download PDFInfo
- Publication number
- JP2014111145A JP2014111145A JP2014000372A JP2014000372A JP2014111145A JP 2014111145 A JP2014111145 A JP 2014111145A JP 2014000372 A JP2014000372 A JP 2014000372A JP 2014000372 A JP2014000372 A JP 2014000372A JP 2014111145 A JP2014111145 A JP 2014111145A
- Authority
- JP
- Japan
- Prior art keywords
- flexible tube
- cannula
- flexible
- surgical
- overlapping
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Granted
Links
Images






Classifications
-
- A—HUMAN NECESSITIES
- A61—MEDICAL OR VETERINARY SCIENCE; HYGIENE
- A61M—DEVICES FOR INTRODUCING MEDIA INTO, OR ONTO, THE BODY; DEVICES FOR TRANSDUCING BODY MEDIA OR FOR TAKING MEDIA FROM THE BODY; DEVICES FOR PRODUCING OR ENDING SLEEP OR STUPOR
- A61M25/00—Catheters; Hollow probes
- A61M25/01—Introducing, guiding, advancing, emplacing or holding catheters
- A61M25/0105—Steering means as part of the catheter or advancing means; Markers for positioning
- A61M25/0108—Steering means as part of the catheter or advancing means; Markers for positioning using radio-opaque or ultrasound markers
-
- A—HUMAN NECESSITIES
- A61—MEDICAL OR VETERINARY SCIENCE; HYGIENE
- A61B—DIAGNOSIS; SURGERY; IDENTIFICATION
- A61B17/00—Surgical instruments, devices or methods
- A61B17/34—Trocars; Puncturing needles
- A61B17/3417—Details of tips or shafts, e.g. grooves, expandable, bendable; Multiple coaxial sliding cannulas, e.g. for dilating
- A61B17/3421—Cannulas
-
- A—HUMAN NECESSITIES
- A61—MEDICAL OR VETERINARY SCIENCE; HYGIENE
- A61B—DIAGNOSIS; SURGERY; IDENTIFICATION
- A61B17/00—Surgical instruments, devices or methods
- A61B17/34—Trocars; Puncturing needles
- A61B17/3478—Endoscopic needles, e.g. for infusion
-
- A—HUMAN NECESSITIES
- A61—MEDICAL OR VETERINARY SCIENCE; HYGIENE
- A61M—DEVICES FOR INTRODUCING MEDIA INTO, OR ONTO, THE BODY; DEVICES FOR TRANSDUCING BODY MEDIA OR FOR TAKING MEDIA FROM THE BODY; DEVICES FOR PRODUCING OR ENDING SLEEP OR STUPOR
- A61M25/00—Catheters; Hollow probes
- A61M25/01—Introducing, guiding, advancing, emplacing or holding catheters
- A61M25/0105—Steering means as part of the catheter or advancing means; Markers for positioning
- A61M25/0127—Magnetic means; Magnetic markers
-
- A—HUMAN NECESSITIES
- A61—MEDICAL OR VETERINARY SCIENCE; HYGIENE
- A61M—DEVICES FOR INTRODUCING MEDIA INTO, OR ONTO, THE BODY; DEVICES FOR TRANSDUCING BODY MEDIA OR FOR TAKING MEDIA FROM THE BODY; DEVICES FOR PRODUCING OR ENDING SLEEP OR STUPOR
- A61M25/00—Catheters; Hollow probes
- A61M25/01—Introducing, guiding, advancing, emplacing or holding catheters
- A61M25/0105—Steering means as part of the catheter or advancing means; Markers for positioning
- A61M25/0133—Tip steering devices
- A61M25/0152—Tip steering devices with pre-shaped mechanisms, e.g. pre-shaped stylets or pre-shaped outer tubes
-
- A—HUMAN NECESSITIES
- A61—MEDICAL OR VETERINARY SCIENCE; HYGIENE
- A61B—DIAGNOSIS; SURGERY; IDENTIFICATION
- A61B1/00—Instruments for performing medical examinations of the interior of cavities or tubes of the body by visual or photographical inspection, e.g. endoscopes; Illuminating arrangements therefor
- A61B1/005—Flexible endoscopes
- A61B1/0051—Flexible endoscopes with controlled bending of insertion part
- A61B1/0055—Constructional details of insertion parts, e.g. vertebral elements
-
- A—HUMAN NECESSITIES
- A61—MEDICAL OR VETERINARY SCIENCE; HYGIENE
- A61B—DIAGNOSIS; SURGERY; IDENTIFICATION
- A61B17/00—Surgical instruments, devices or methods
- A61B17/00234—Surgical instruments, devices or methods for minimally invasive surgery
- A61B2017/00292—Surgical instruments, devices or methods for minimally invasive surgery mounted on or guided by flexible, e.g. catheter-like, means
- A61B2017/003—Steerable
- A61B2017/00318—Steering mechanisms
- A61B2017/00331—Steering mechanisms with preformed bends
-
- A—HUMAN NECESSITIES
- A61—MEDICAL OR VETERINARY SCIENCE; HYGIENE
- A61B—DIAGNOSIS; SURGERY; IDENTIFICATION
- A61B17/00—Surgical instruments, devices or methods
- A61B2017/00367—Details of actuation of instruments, e.g. relations between pushing buttons, or the like, and activation of the tool, working tip, or the like
- A61B2017/00398—Details of actuation of instruments, e.g. relations between pushing buttons, or the like, and activation of the tool, working tip, or the like using powered actuators, e.g. stepper motors, solenoids
-
- A—HUMAN NECESSITIES
- A61—MEDICAL OR VETERINARY SCIENCE; HYGIENE
- A61B—DIAGNOSIS; SURGERY; IDENTIFICATION
- A61B17/00—Surgical instruments, devices or methods
- A61B2017/00743—Type of operation; Specification of treatment sites
- A61B2017/00809—Lung operations
-
- A—HUMAN NECESSITIES
- A61—MEDICAL OR VETERINARY SCIENCE; HYGIENE
- A61B—DIAGNOSIS; SURGERY; IDENTIFICATION
- A61B34/00—Computer-aided surgery; Manipulators or robots specially adapted for use in surgery
- A61B34/30—Surgical robots
- A61B2034/301—Surgical robots for introducing or steering flexible instruments inserted into the body, e.g. catheters or endoscopes
-
- A—HUMAN NECESSITIES
- A61—MEDICAL OR VETERINARY SCIENCE; HYGIENE
- A61M—DEVICES FOR INTRODUCING MEDIA INTO, OR ONTO, THE BODY; DEVICES FOR TRANSDUCING BODY MEDIA OR FOR TAKING MEDIA FROM THE BODY; DEVICES FOR PRODUCING OR ENDING SLEEP OR STUPOR
- A61M25/00—Catheters; Hollow probes
- A61M25/01—Introducing, guiding, advancing, emplacing or holding catheters
- A61M25/0105—Steering means as part of the catheter or advancing means; Markers for positioning
- A61M25/0133—Tip steering devices
- A61M2025/0161—Tip steering devices wherein the distal tips have two or more deflection regions
Landscapes
- Health & Medical Sciences (AREA)
- Life Sciences & Earth Sciences (AREA)
- Animal Behavior & Ethology (AREA)
- General Health & Medical Sciences (AREA)
- Veterinary Medicine (AREA)
- Engineering & Computer Science (AREA)
- Biomedical Technology (AREA)
- Heart & Thoracic Surgery (AREA)
- Public Health (AREA)
- Surgery (AREA)
- Pathology (AREA)
- Molecular Biology (AREA)
- Medical Informatics (AREA)
- Nuclear Medicine, Radiotherapy & Molecular Imaging (AREA)
- Biophysics (AREA)
- Pulmonology (AREA)
- Anesthesiology (AREA)
- Hematology (AREA)
- Surgical Instruments (AREA)
- Infusion, Injection, And Reservoir Apparatuses (AREA)
Abstract
【解決手段】能動的カニューレ102は、複数の重なり合う可撓性チューブ110,115,120を有し、これらチューブの各々は予め形成された湾曲及び所定の可撓性を有する。複数の可撓性チューブの各々は、患者の体内を通る所望の経路にほぼ合致する所定の形状を形成する重なり合う可撓性チューブの組合せを提供する重複構造を与えるような、それぞれの所定の湾曲と可撓性とに基づいて選択される。可撓性チューブの各々の平行移動及び角度方向を独立して制御することにより、患者体内の所望の経路に従って外科縫合針を導くことができる。
【選択図】図1
Description
本発明は概して、侵襲が最小となるような手術を行うための外科用カニューレ及びバイオセンサに関する。具体的には、本発明は、外科用器具、注入可能物、診断デバイス、及び/又はバイオセンサを複雑な軌跡を通して導くためのデバイスと方法に関する。
近年の、侵襲を最小にする外科技術(MIS)は、一般に伝統的な切開手術に起因する大規模な外傷を生じない外科的処置を可能にすることにより医学を革新した。MIS技術は、従来の切開手術技術では到達不可能だった解剖学的構造領域に医師がアクセスして処置を行うことを可能にした。更にMIS技術は、手術に伴う外傷を大きく減少させ、これにより手術に関連する合併症を減らし、術後の回復を促進させた。実現性のあるMISの代替技術無しで、人体(特に、頭部及び頸部)内部の閉じ込められたスペースにおける手術を行うには、単に手術部位への術具のアクセスを可能にするのに、健康な骨、皮膚、及び筋肉構造の大規模な切開と破壊的な解体が必要である。
関連技術によるMISツールは剛性の腹腔鏡デバイスを含み、このデバイスは、手術で器用な動きをするために体の内部及び外部の両方に大きな開放スペースを要する。開放スペースに対するこの要件は概して、多くの種類の手術において腹腔鏡デバイスの使用を妨げる。関連技術による他のMISツールは可撓性の形状記憶合金デバイスを含み、この場合デバイスの形状は、デバイスが患者の体内で案内される際に形状記憶合金に熱を加えることにより変更が可能である。このようなデバイスの1つの問題は、周囲の組織に意図せずに熱を加えてしまうことである。別の問題は、形状記憶合金の熱時定数が、加えた適切な熱が放散するのにかなりの時間(数秒に亘る)を要することである。これらの熱時定数によって生じる遅れはこのようなMISデバイスの使用を制限する。
頭部及び頸部に関する外科的処置は、MIS技術の出現をもってしても特に難題である。例えば、頭蓋底における病変の処置では、一般に、鼻を通してMISデバイスを内視鏡的に挿入する。関連技術によるMISデバイスは、洞内の小さな開口部を迂回して又は通って曲がる器用さに欠けるので、頭蓋底を含む種々の手術部位にMISデバイスを到達させるために、鼻甲介のような多くの健康な組織及び骨構造を除去しなければならない。鼻甲介に関し、その通常の機能は、空気を浄化すること及び嗅覚を助けることである。手術部位へのアクセスのために除去されてしまうと、その機能が回復するような方法で鼻甲介を再構築することはできない。関連技術による直線的MISデバイスを用いて到達できない手術部位の例を二つ挙げると、頚動脈の後の区域(眼底の近く)及び前頭洞で、これらの区域は鼻柱の直ぐ後に位置する骨を迂回して到達する操作を要する。
従って、必要とされるのは、他の手法では到達不可能な手術部位に到達するために、解剖学的身体部分を迂回して操作できる器用さを有する手術具である。更に、必要とされるのは、組織媒体だけでなく、洞、喉、及び肺のような空洞内の自由空間を通して動かすことが可能な手術デバイスである。
本発明の別の利点は、対象となる組織領域への到達過程で組織が受ける付帯的外傷を低減することである。
本発明の更に別の利点は、治療及び診断のための針の解剖学的特徴の到達能を増大させることである。
本発明の更に別の利点は、外科用カニューレの小型化が進むことである。
上記以外の本発明の利点は以下の説明で開示され、その一部は説明から明らかになるか、又は本発明の実施により教示される。本発明の利点は、添付図面だけでなく、本明細書及び特許請求の範囲において指摘される構造によって実現され、取得される。
本発明は、中に外科針を配置することができる能動的カニューレ(外科用カニューレとも称する)に関する。能動的カニューレは、蛇状外科用ロボットとも称される。能動的カニューレは、複数の同心の可撓性中空チューブを有し、各チューブは所定の可撓性と予め形成された湾曲とを有する。能動的カニューレの先端部は、可撓性チューブの各々を選択的に平行移動及び回転させることにより前進する。能動的カニューレは、各可撓性チューブの可撓性、予め形成された湾曲、角度方向、及び平行移動位置に応じて、自由空間(例えば、洞の通路又は気管支の気道内で)及び/又は異なる抵抗を有する組織内における能動的カニューレの操作を可能にする計画された複雑形状を取るように操作することができる。能動的カニューレの形状は組織媒体の抵抗による影響も受ける。この場合、組織媒体の抵抗を利用して、能動的カニューレを導くことができる。能動的カニューレは、可撓性チューブが平行移動及び回転の間に互いに対してスライドする際に可撓性チューブの各々に蓄積される弾性エネルギーによって連続的に作動することができる。
更に、同心の可撓性チューブの相互作用力を介して「内部で押し合うこと」により、自由空間内又は組織媒体内を通って導かれながら、能動的カニューレは複雑な形状を取ることができる。これは、手術針を、軟組織又は動脈壁のような解剖学的形状で有り得る組織媒体に押し付けることにより導く関連技術の方法と対照的である。
制御コンピュータ145は、制御ネットワーク接続146aを介してホストコンピュータ150に接続される。ホストコンピュータ150と制御コンピュータ145とが同じ場所に配置されている場合、制御ネットワーク接続146aはローカルエリアネットワーク(LAN)である。別の構成として、ホストコンピュータ150と制御コンピュータ145は大きく距離を隔てて配置することができ、その場合制御ネットワーク接続146aはインターネットを含むことができる。
システム100は更に、医療用画像化システム160を含むことができ、この医療用画像化システム160は画像プロセッサ165を有する。画像プロセッサ165は、画像化ネットワーク接続146bを介してホストコンピュータ150に接続することができ、画像化ネットワーク接続146bは、制御ネットワーク接続146aと同じ種類のネットワーク接続とすることができる。
医療用画像化システム160は、蛍光透視、MRI、超音波等の、1以上の医療用画像化態様を含むことができる。医療用画像化システム160の特定の画像化態様は、能動的カニューレ102に用いられる材料と、能動的カニューレ102を用いる患者の体170の性質とに応じて決定することができる。医療用画像化システム160は、ホストコンピュータ150上で動くソフトウェアによる能動的カニューレ102の画像に基づくフィードバック制御を可能にするのに十分な適時性及び十分なフレーム率を有する3次元画像を提供する種類のものとすることができる。
外部可撓性チューブ110は、ニチノール等の形状記憶合金を用いて作製できるが、外科的使用に適し、例えば材料特性によって、又はチューブ壁の厚さを指定することによって予め定めることの可能な可撓性を有するものであれば、他の材料を使用することもできる。
外部可撓性チューブ110の場合と同様に、中間可撓性チューブ115は、ニチノール等の形状記憶合金を用いて作製できるが、外科的使用に適し、例えばチューブに特定の厚さを指定することによって予め定めることの可能な可撓性を有するものであれば、他の材料を試用することもできる。更に、中間可撓性チューブ115には、能動的カニューレ102に意図された形状、厚さ、及び全体的可撓性に応じて、外部可撓性チューブ110と同じ材料を用いても用いなくてもよい。
外部可撓性チューブ110の場合と同様に、内部可撓性チューブ120は、ニチノール等の形状記憶合金を用いて作製できるが、外科的使用に適し、例えばチューブに特定の厚さを指定することによって予め定めることの可能な可撓性を有するものであれば、他の材料を用いることもできる。更に、内部可撓性チューブ120には、外部可撓性チューブ110及び中間可撓性チューブ115と同じ材料を用いても用いなくてもよい。
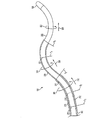
図2Dは、図2A〜図2Cに示される各チューブを含む能動的カニューレ102を示す。内部可撓性チューブ120は中間可撓性チューブ115内に挿入されており、内部可撓性チューブ120と中間可撓性チューブ115との組合せは外部可撓性チューブ110内に挿入されている。
図3に示すように、能動的カニューレ102は複数の重なり合い移行点T1〜T5を有する。各重なり合い移行点T1〜T5は、外部可撓性チューブ110、中間可撓性チューブ115、及び内部可撓性チューブ120(又はこれら3つのチューブのいずれかの部分集合)の各々がほぼ一定の湾曲度を有するか又は湾曲を欠如する領域の境界を画定する。例えば、重なり合い移行点T1とT2の間の領域は、外部チューブ湾曲区分212と、中間チューブ直線区分215と、内部チューブ直線区分220とを含む。重なり合い移行点T2は、中間チューブ移行点216と一致する。従って、重なり合い移行点T2とT3の間の領域は、外部チューブ湾曲区分212と、中間チューブ湾曲区分217と、内部チューブ直線区分220とを含む。
図4Bは、本発明による例示的な2軸作動器405を示す。2軸作動器405は、外部駆動モジュール130、中間駆動モジュール135、及び内部駆動モジュール140のいずれに用いてもよい。2軸作動器405は、可撓性チューブ(例として外部可撓性チューブ110を示す)に堅固に取り付けることが可能な案内ねじ棒410と、案内ねじ棒410にねじ係合するナット415と、平行移動歯車425を介してナット415に結合される直線平行移動モータ435とを含む。2軸作動器405は更に、スプロケット437を介して案内ねじ棒410に結合されるベルト駆動部440を含む。ベルト駆動部440は、回転歯車445を介して回転モータ450にも結合される。2軸作動器405はまた、制御コンピュータ145に直線平行移動位置と角度方向の信号をそれぞれ供給する平行移動及び回転エンコーダ(図示しない)を含むことができる。
回転の場合、回転モータ450が、制御コンピュータ145から、特定の回転角だけその可撓性チューブを回転させるようにとの命令を受ける。これに応答して、回転モータ450は回転歯車445を回転させ、この回転歯車445はベルト駆動部440と係合する。ベルト駆動部440はスプロケット437と係合し、次にスプロケット437が案内ねじ棒410を回転させる。このような案内ねじ棒410の回転が、ナット415の存在によって案内ねじ棒410を平行移動させることに留意されたい。従って、寄生的な平行移動を防止するために、直線平行移動モータ435はナット415を反対方向に回転させることによって補償を行う。従って、可撓性チューブの純粋な回転には、回転モータ450と直線平行移動モータ435との負時の調和が必要である。
2軸作動器には様々な変形例が可能である。例えば、2軸作動器405は、それぞれ直線平行移動モータ435及び回転モータ450に優先して作動するノブのような手動制御器を含むことができる。更に、システム100は、モータ駆動式作動器と手動作動式との組み合わせを含むことができる。更に、2軸作動器は例示的なものである。従って、ここに示す方法以外に、可撓性チューブの各々の直線平行移動及び回転を行う他の方法が可能である。当業者であれば、本発明の範囲内で多数のこのような変形が可能であることを容易に理解するであろう。
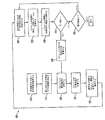
ステップ605において、医療用画像化システム160は患者の体170の内部の画像を取得する。医療用画像化システム160は、進入点175及び手術部位180を含む視野を有するように構成することができる。その画像化態様(例えば、MRI、超音波等)により、医療用画像化システム160は、画像の各画素又は3D画素が画像座標フレームに登録されている患者の体の三次元画像を取得することができる。画像プロセッサ165は、画像、並びに画像登録情報を、画像化ネットワーク接続146bを介してホストコンピュータ150に供給することができる。
医師は、経路及びその誤境界を画定するためのユーザインタフェース155を用いることができる。その際、医師は、ステップ605において取得された登録画像内部の点にタグをつけるためにカーソルを用いることができる。ソフトウェアは、登録画像中のこれら選択された点の位置を特定し、これらの位置をメモリ152に記憶する。
経路に適合した最終構成を計算するため、ソフトウェアは、重なり合い移行点T1〜T5によって画定される一組の領域に能動的カニューレ102を分割する。その際、ソフトウェアは、外部可撓性チューブ110及び中間可撓性チューブ115の各々について、平行移動位置と回転方向位置との最初の組を選択することができる。重なり合い移行点T1〜T5の位置は、3つの可撓性チューブの重なり合いに依存する。次いで、重なり合い移行点T1〜T5により画定された各領域について、ソフトウェアが、次の関係式により、その領域における瞬時的平衡曲線(x及びy成分)を計算する。

ここで、nは可撓性チューブの数(本実施例ではn=3)であり、κiはその領域内でのi番目の可撓性チューブの瞬時的湾曲であり、Eiは当該i番目の可撓性チューブの材料の弾性係数(ヤング係数)であり、Iiはi番目の可撓性チューブの横断面慣性モーメントであり、θiは作動器の方向で最も近い重なり合い移行点Tにおけるi番目の可撓性チューブの角度方向であり、φは、組み合わされた可撓性チューブの個別の角度方向が既知である場合のこれら組み合わせの平衡角であり、φは当該領域の底部において決定される。言い換えれば、例えば、重なり合い移行点T3とT4によって画定された領域のφは、T3における平衡角に関係する。
ここで、αiは、内部駆動モジュール140、中間駆動モジュール135、及び外部駆動モジュール130に入力される角度であり、θi,jはj番目の移行点Tjにおけるi番目の可撓性チューブの角度であり、φ1,φ2,・・・φmは、重なり合い移行点Tの間のm個の重なり合い領域の各々の平衡平面であり、q=(θ1,1,θ1,2,・・・θ1,n,φ1,φ2,・・・φm)である。E(q)の最小値を解くことで、移行点T1における回転方向θ1,1,θ1,2,・・・θ1,n、及び移行点T間の各重なり領域の平衡平面φ1,φ2,・・・φmが得られる。これらの値はまた、能動的カニューレ102の移行点T間の各重なり領域における湾曲を計算するために、上記等式のκx及びκyに用いることができる。
図7は、可撓性チューブを制御するための運動フレームを示す。図示のように、φは重なり合い移行点Tiにおける可撓性チューブ710の平衡角を示し、αは2軸作動器405の回転モータによって伝達される入力回転角を示す。
ステップ620では、ソフトウェアは、ステップ615において計算された最終構成を徐々に達成でき、医師によって決定された経路及び誤境界以外に位置することのない能動的カニューレ102の複数の構成を計算する。その際、ソフトウェアは、一連の中間構成を計算し、各中間構成を達成する一組の直線平行移動及び回転を計算することができる。ソフトウェアは、計算された各中間構成を次に計算される中間構成の初期構成としながら、上記ステップ615において行われた計算とほぼ同様の計算を反復的に行うことができる。
ステップ625では、ソフトウェアは、ステップ615及びステップ620においてそれぞれ計算された能動的カニューレの最終及び中間構成を、医療用画像化システム160の座標フレームに登録する。その際、ソフトウェアは、ステップ605において取得された登録画像に、ステップ610において医師が経路を指定したものを取り出し、能動的カニューレ102の最終及び中間構成を登録することができる。この結果、1の中間構成につき1の曲線と最終構成の1の曲線とからなる一組の曲線が得られ、各組の湾曲は重なり合い移行点T1〜T5の間の能動的カニューレ102の領域に対応する。ソフトウェアはこれを、能動的カニューレの起点(画像スペースに登録されている)から開始して、進入点175を通り、手術部位180で(又は中間構成における能動的カニューレ102のエンドエフェクタ125において)で終結することによって行うことができる。ソフトウェアはこれらの湾曲の組をメモリ152に格納する。
実行サブプロセスの第1のステップであるステップ630において、医師は(ユーザインタフェース155を介して)ソフトウェアに対し、ステップ620(経路計画サブプロセス)で計算された第1の中間構成へ能動的カニューレ102を動かすように命令する。その際、ホストコンピュータ150及び/又は制御コンピュータ145上で実行されるソフトウェアは、ステップ620で計算された第1の中間構成を達成するように外部駆動モジュール130、中間駆動モジュール135、及び内部駆動モジュール140の各々の平行移動モータ435及び回転モータ450に対し、適切に命令する。
ステップ640では、ソフトウェアは、能動的カニューレ102の登録画像を、ステップ620で計算された中間構成と比較する。その際、ソフトウェアは、2つの画像を比較するための多数の画像処理アルゴリズムのうちの1以上を利用することができる。更に、ソフトウェアは、セグメント化されて登録された能動的カニューレ102の座標を、所与の中間構成の計算された座標と比較し、この比較に基づいて経路誤り又は微分変位を計算することができる。
ステップ655では、ソフトウェアは、所与の中間構成がステップ615において計算された最終構成であるかどうかを決定する。そうである場合、プロセス600はステップ655から「はい」の分岐を通って進み、終了する。最終構成でない場合、プロセス600はステップ655の「いいえ」の分岐を通って進み、次の中間構成(又は最終構成)についてステップ630〜645を繰り返す。
ステップ650では、ソフトウェアにより、ステップ630において能動的カニューレ102が患者の体170を通して押し込まれた際に能動的カニューレ102に加わる力及びトルクを計算する。ソフトウェアは、次の関係式によってこの力及びトルクを計算することができる。
ここで、fx,y,zは2つの重なり合い移行点Ti及びTi+1の間の所与の領域において組織媒体によって能動的カニューレ102上に伝達される力の成分であり、τx,y,zは、同じ領域において組織媒体によって能動的カニューレ102上に伝達されるトルクであり、dispx,y,zは、ステップ640において計算された能動的カニューレ102の微分変位の平行移動成分であり、rotx,y,zは、ステップ640において計算された能動的カニューレ102の微分変位の回転成分であり、Kはコンプライアンス行列である。この行列は、2つの重なり合い移行点TiとTi+1の間の所与の領域の能動的カニューレ102の力とトルクのコンプライアンスに対応する6X6行列である。
ここで、dは可撓性チューブの直径であり、εは可撓性チューブの材料の、復元可能な最大ひずみである。ニチノールのεは、0.08〜0.1である。上記の関係式から推測できるように、可撓性チューブが細いほど最大湾曲度は大きく(又は最小曲率半径が小さく)なる。従って、ステップ610で医師により決定された経路によっては、チューブは細い方が望ましい。ソフトウェアは、ステップ610において決定された経路に応じて医師が可撓性チューブの好ましい太さを選択するのを援助する。
能動的カニューレ102、システム100、及びプロセス600の変形例が可能であり、且つ本発明の範囲に含まれる。例えば、能動的カニューレ102内の可撓性チューブの一部又は全部は、ほぼ同じ度合いの可撓性を有してもよく、又は異なる度合いの可撓性を有してもよい。可撓性チューブのすべてが同様の可撓性を有する場合、能動的カニューレ102の動きは機敏となり、複雑な経路内を容易に導くことができる。別の構成では、外部可撓性チューブ110を中間可撓性チューブ115より堅くし、中間可撓性チューブ115を内部可撓性チューブ120より堅くすることができる。この場合、能動的カニューレ102の機敏さは前記実施例(全ての可撓性チューブが同じ可撓性を有する)より低下する。しかしながら、後者の場合、能動的カニューレ102の経路は計算し易く、例えば図5に示した手動2軸作動器505を用いることにより、手動操作能が向上する。
能動的カニューレ102内の任意の可撓性チューブは、1の湾曲区分のみ又は1の直線区分のみを有してもよい。更に、任意の可撓性チューブは、各々が異なる湾曲度合い(湾曲のない場合を含む)を備える複数のセグメントを有することができる。これにより、能動的カニューレ102は更に複雑な形状を取ることが可能になる。例えば、任意の可撓性チューブは、一連の3次元湾曲と直線領域とを有することができる。また、任意の可撓性チューブは、らせん形状、楕円形状、放物線形状、3次元での可変湾曲等の複雑な形状を持つセグメントを有することができる。これらの場合のいずれにおいても、特定の可撓性チューブの曲率半径の変化を表わす複数の移行点(内部チューブ移行点221、中間チューブ移行点216、及び外部チューブ移行点211等)を画定することができる。従って、ステップ615及びステップ620におけるカニューレの最終及び中間構成の計算の一部において、重なり合い領域を画定するために、湾曲の個別の段階をセグメント化することができる。
別の変更例では、1以上の可撓性チューブは基準となる指標を有することができ、これらの基準はチューブ材料に埋め込むことができ、医療用画像化システム160に可視となるように設計することができる。例えば、医療用画像化システム160が光学カメラである場合、埋め込まれる基準は、色付きの縞、又は明色と暗色の縞の形態を取ることができる。更に、医療用画像化システムがCアーム透視装置である場合、埋め込まれる基準は、チューブ材料に植え込まれたワイヤ構造を含むことができる。当業者であれば、多数のこのような変形が可能であり且つ本発明の範囲に含まれることを理解するであろう。
上述の肺及び咽頭の手術に加えて、本発明は、能動的カニューレ102及びシステム100により付与される器用さが有利となる他の手術法にも使用できる。このような手術法には高周波切除が含まれる。高周波切除においては、手術部位に電極が置かれ、電極の周囲の組織を加熱するために、無痛高周波エネルギーが伝達される。この手術法は、肝臓、腎臓、及び肺の腫瘍の治療の一部として細胞を殺すために用いられる。能動的カニューレ102及びシステム100は、電極を配置するのに用いることができる。
別の可能な外科的適用途には経胃手術が含まれ、この場合、口から術具を胃に挿入し、胃から腹腔に出す。能動的カニューレ102の、器用さ、並びに自由空間及び組織内を導き易い性質は、経胃手術を可能にすることができる。
上記の説明は本発明の外科的用途に関するが、当業者であれば、自由空間を伴う複雑な経路を通してデバイスを導く必要がある他の用途に使用できることを理解するであろう。他の用途には、製造及び微細組立、遠隔構造検査、兵器の信管除去、崩壊した構造物内部での捜索及び救出等が含まれる。
Claims (23)
- 第1の予め形成された湾曲を有する第1の可撓性チューブ、
第2の予め形成された湾曲を有する第2の可撓性チューブであって、第1の可撓性チューブの内部に配置される第2の可撓性チューブ、
第1の可撓性チューブに結合された第1の作動器であって、第1の可撓性チューブの平行移動及び回転を制御する第1の作動器、及び
第2の可撓性チューブに結合された第2の作動器であって、第2の可撓性チューブの回転及び平行移動を、第1の可撓性チューブの平行移動及び回転とは関係なく制御する第2の作動器
を備える外科用カニューレ。 - 第1の可撓性チューブが第2の可撓性チューブよりも堅い、請求項1に記載の外科用カニューレ。
- 第1の可撓性チューブが第1の剛性を有し、第2の可撓性チューブが第2の剛性を有し、第1の剛性と第2の剛性がほぼ等しい、請求項1に記載の外科用カニューレ。
- 第1の可撓性チューブがニチノールを含む、請求項1に記載の外科用カニューレ。
- 第1の可撓性チューブが直線部分を有する、請求項1に記載の外科用カニューレ。
- 第1の可撓性チューブが複雑な形状を有する領域を含む、請求項1に記載の外科用カニューレ。
- 第1の可撓性チューブが、それぞれ厚さの異なる複数の領域を含む、請求項1に記載の外科用カニューレ。
- 第2の可撓性チューブがニチノールを含む、請求項1に記載の外科用カニューレ。
- 第2の可撓性チューブが直線部分を有する、請求項1に記載の外科用カニューレ。
- 第2の可撓性チューブが複雑な形状を有する領域を含む、請求項1に記載の外科用カニューレ。
- 第2の可撓性チューブが、それぞれ厚さの異なる複数の領域を含む、請求項1に記載の外科用カニューレ。
- 更に、第1の作動器と第2の作動器とに接続されたコンピュータを含み、このコンピュータが、第1の可撓性チューブの直線部分の位置、第1の可撓性チューブの角度方向、第1の予め形成された湾曲、第2の可撓性チューブの直線部分の位置、第2の可撓性チューブの角度方向、第2の予め形成された湾曲、及び第1の可撓性チューブと第2の可撓性チューブの重なり合いに基づいて外科用カニューレの形状を決定するプログラムにより符号化された、コンピュータで読取り可能な媒体を備える、請求項1に記載の外科用カニューレ。
- 第3の予め形成された湾曲を有する第3の可撓性チューブであって、第2の可撓性チューブの内部に配置される第3の可撓性チューブ、及び
第3の可撓性チューブに結合された第3の作動器
を更に備える、請求項1に記載の外科用カニューレ。 - 更に、第1の作動器、第2の作動器、及び第3の作動器に接続されたコンピュータを備え、このコンピュータが、第1の可撓性チューブの直線部分の位置、第1の可撓性チューブの角度方向、第1の予め形成された湾曲、第2の可撓性チューブの直線部分の位置、第2の可撓性チューブの角度方向、第2の予め形成された湾曲、第3の可撓性チューブの直線部分の位置、第3の可撓性チューブの角度方向、第3の予め形成された湾曲、第1の可撓性チューブと第2の可撓性チューブと第3の可撓性チューブとの重なり合いに基づいて外科用カニューレの形状を決定するプログラムにより符号化された、コンピュータで読取り可能な媒体を備える、請求項13に記載の外科用カニューレ。
- 外科用カニューレを導くためのソフトウェアにより符号化されたコンピュータで読取り可能な媒体であって、当該ソフトウェアが、
所望のカニューレ経路を受け取るプログラム、
所望のカニューレ経路にほぼ合致する複数の重なり合う可撓性チューブの構成を計算するプログラム、
所望のカニューレ経路に対応する複数の中間的構成を計算するプログラム、及び
複数の中間的構成に従って複数の作動器に命令するプログラム
を含む、コンピュータで読取り可能な媒体。 - ソフトウェアが更に、
カニューレの画像を取得するプログラム、
画像内のカニューレの位置を登録するプログラム、及び
カニューレの位置を所望のカニューレ経路と比較するプログラム
を含む、請求項15に記載のコンピュータで読み取り可能な媒体。 - ソフトウェアが更に、カニューレに加わる力及びトルクを計算するプログラムを含む、請求項16に記載のコンピュータで読取り可能な媒体。
- 複数の重なり合う可撓性チューブの構成を計算するプログラムが、
複数の重なり合う領域を特定するプログラム、及び
重なり合う領域の各々の内部の、複数の重なり合う可撓性チューブの各々の予め形成された湾曲と、重なり合う可撓性チューブの各々の可撓性とに基づいて、複数の重なり合う領域の各々の湾曲を計算するプログラム
を含む、請求項15に記載のコンピュータで読取り可能な媒体。 - 複数の重なり合う可撓性チューブを有する外科用カニューレを導く方法であって、
所望のカニューレ経路を決定するステップ、
各々が予め定め形成された湾曲と可撓性とを有する、複数の可撓性チューブを選択するステップ、
結果として得られる重なり合い構成の湾曲が所望のカニューレ経路にほぼ対応するように、複数の可撓性チューブの最終的な重なり合い構成を決定するステップ、及び
各々が所望のカニューレ経路に対応する、複数の可撓性チューブの複数の中間的重なり合い構成を決定するステップ
を含む方法。 - 最終的な重なり合い構成を決定するステップが、複数の重なり合う可撓性チューブの各々の平行移動及び回転を決定するステップを含む、請求項19に記載の方法。
- 複数の中間的重なり合い構成の各々に従って、複数の可撓性チューブの各々を平行移動及び回転させるステップを更に含む、請求項19に記載の方法。
- 最終的な重なり合い構成を決定するステップが、
複数の重なり合う可撓性チューブの各々に対応する平行移動及び回転の最初の組を選択するステップ、
平行移動及び回転の最初の組に対応する複数の重なり合う領域を特定するステップ、及び
複数の重なり合う領域の各々に対応する瞬間的湾曲を計算するステップ
を含む、請求項19に記載の方法。 - 複数の重なり合う領域の各々に対応する瞬間的湾曲を計算するステップが、
外科用カニューレの直線区分に対応する捩れエネルギーを計算するステップ、
外科用カニューレに対応する曲げエネルギーを計算するステップ、及び
最小の捩れエネルギーと最小の曲げエネルギーとに対応する外科用カニューレの形状を求めるステップ
を含む、請求項22に記載の方法。
Applications Claiming Priority (4)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| US73678905P | 2005-11-15 | 2005-11-15 | |
| US60/736,789 | 2005-11-15 | ||
| US84978806P | 2006-10-06 | 2006-10-06 | |
| US60/849,788 | 2006-10-06 |
Related Parent Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| JP2012139088A Division JP5550682B2 (ja) | 2005-11-15 | 2012-06-20 | バイオセンシング及び外科的処置のための能動的カニューレ |
Related Child Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| JP2015094824A Division JP6290822B2 (ja) | 2005-11-15 | 2015-05-07 | バイオセンシング及び外科的処置のための能動的カニューレ |
Publications (2)
| Publication Number | Publication Date |
|---|---|
| JP2014111145A true JP2014111145A (ja) | 2014-06-19 |
| JP5964335B2 JP5964335B2 (ja) | 2016-08-03 |
Family
ID=38049282
Family Applications (4)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| JP2008541319A Active JP5276987B2 (ja) | 2005-11-15 | 2006-11-15 | バイオセンシング及び外科的処置のための能動的カニューレ |
| JP2012139088A Active JP5550682B2 (ja) | 2005-11-15 | 2012-06-20 | バイオセンシング及び外科的処置のための能動的カニューレ |
| JP2014000372A Active JP5964335B2 (ja) | 2005-11-15 | 2014-01-06 | バイオセンシング及び外科的処置のための能動的カニューレ |
| JP2015094824A Active JP6290822B2 (ja) | 2005-11-15 | 2015-05-07 | バイオセンシング及び外科的処置のための能動的カニューレ |
Family Applications Before (2)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| JP2008541319A Active JP5276987B2 (ja) | 2005-11-15 | 2006-11-15 | バイオセンシング及び外科的処置のための能動的カニューレ |
| JP2012139088A Active JP5550682B2 (ja) | 2005-11-15 | 2012-06-20 | バイオセンシング及び外科的処置のための能動的カニューレ |
Family Applications After (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| JP2015094824A Active JP6290822B2 (ja) | 2005-11-15 | 2015-05-07 | バイオセンシング及び外科的処置のための能動的カニューレ |
Country Status (6)
| Country | Link |
|---|---|
| US (2) | US8152756B2 (ja) |
| EP (1) | EP1973595B1 (ja) |
| JP (4) | JP5276987B2 (ja) |
| CN (1) | CN101351236B (ja) |
| CA (1) | CA2630061C (ja) |
| WO (1) | WO2007059233A2 (ja) |
Families Citing this family (609)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| US6770080B2 (en) | 2001-04-26 | 2004-08-03 | Fenestra Medical, Inc. | Mechanically registered videoscopic myringotomy/tympanostomy tube placement system |
| US8066674B2 (en) * | 2003-01-27 | 2011-11-29 | Heuser Richard R | Catheter introducer system |
| US20070084897A1 (en) | 2003-05-20 | 2007-04-19 | Shelton Frederick E Iv | Articulating surgical stapling instrument incorporating a two-piece e-beam firing mechanism |
| US9060770B2 (en) | 2003-05-20 | 2015-06-23 | Ethicon Endo-Surgery, Inc. | Robotically-driven surgical instrument with E-beam driver |
| US11890012B2 (en) | 2004-07-28 | 2024-02-06 | Cilag Gmbh International | Staple cartridge comprising cartridge body and attached support |
| US9072535B2 (en) | 2011-05-27 | 2015-07-07 | Ethicon Endo-Surgery, Inc. | Surgical stapling instruments with rotatable staple deployment arrangements |
| US8215531B2 (en) | 2004-07-28 | 2012-07-10 | Ethicon Endo-Surgery, Inc. | Surgical stapling instrument having a medical substance dispenser |
| US11998198B2 (en) | 2004-07-28 | 2024-06-04 | Cilag Gmbh International | Surgical stapling instrument incorporating a two-piece E-beam firing mechanism |
| US11259870B2 (en) | 2005-06-06 | 2022-03-01 | Intuitive Surgical Operations, Inc. | Interactive user interfaces for minimally invasive telesurgical systems |
| EP2289452A3 (en) | 2005-06-06 | 2015-12-30 | Intuitive Surgical Operations, Inc. | Laparoscopic ultrasound robotic surgical system |
| US9237891B2 (en) | 2005-08-31 | 2016-01-19 | Ethicon Endo-Surgery, Inc. | Robotically-controlled surgical stapling devices that produce formed staples having different lengths |
| US7934630B2 (en) | 2005-08-31 | 2011-05-03 | Ethicon Endo-Surgery, Inc. | Staple cartridges for forming staples having differing formed staple heights |
| US7669746B2 (en) | 2005-08-31 | 2010-03-02 | Ethicon Endo-Surgery, Inc. | Staple cartridges for forming staples having differing formed staple heights |
| US10159482B2 (en) | 2005-08-31 | 2018-12-25 | Ethicon Llc | Fastener cartridge assembly comprising a fixed anvil and different staple heights |
| US8365976B2 (en) | 2006-09-29 | 2013-02-05 | Ethicon Endo-Surgery, Inc. | Surgical staples having dissolvable, bioabsorbable or biofragmentable portions and stapling instruments for deploying the same |
| US11484312B2 (en) | 2005-08-31 | 2022-11-01 | Cilag Gmbh International | Staple cartridge comprising a staple driver arrangement |
| US20070194079A1 (en) | 2005-08-31 | 2007-08-23 | Hueil Joseph C | Surgical stapling device with staple drivers of different height |
| US11246590B2 (en) | 2005-08-31 | 2022-02-15 | Cilag Gmbh International | Staple cartridge including staple drivers having different unfired heights |
| US20070106317A1 (en) | 2005-11-09 | 2007-05-10 | Shelton Frederick E Iv | Hydraulically and electrically actuated articulation joints for surgical instruments |
| US11793518B2 (en) | 2006-01-31 | 2023-10-24 | Cilag Gmbh International | Powered surgical instruments with firing system lockout arrangements |
| US20110024477A1 (en) | 2009-02-06 | 2011-02-03 | Hall Steven G | Driven Surgical Stapler Improvements |
| US11224427B2 (en) | 2006-01-31 | 2022-01-18 | Cilag Gmbh International | Surgical stapling system including a console and retraction assembly |
| US20110295295A1 (en) | 2006-01-31 | 2011-12-01 | Ethicon Endo-Surgery, Inc. | Robotically-controlled surgical instrument having recording capabilities |
| US7845537B2 (en) | 2006-01-31 | 2010-12-07 | Ethicon Endo-Surgery, Inc. | Surgical instrument having recording capabilities |
| US8186555B2 (en) | 2006-01-31 | 2012-05-29 | Ethicon Endo-Surgery, Inc. | Motor-driven surgical cutting and fastening instrument with mechanical closure system |
| US20110006101A1 (en) | 2009-02-06 | 2011-01-13 | EthiconEndo-Surgery, Inc. | Motor driven surgical fastener device with cutting member lockout arrangements |
| US11278279B2 (en) | 2006-01-31 | 2022-03-22 | Cilag Gmbh International | Surgical instrument assembly |
| US9861359B2 (en) | 2006-01-31 | 2018-01-09 | Ethicon Llc | Powered surgical instruments with firing system lockout arrangements |
| US8708213B2 (en) | 2006-01-31 | 2014-04-29 | Ethicon Endo-Surgery, Inc. | Surgical instrument having a feedback system |
| US8820603B2 (en) | 2006-01-31 | 2014-09-02 | Ethicon Endo-Surgery, Inc. | Accessing data stored in a memory of a surgical instrument |
| US7753904B2 (en) | 2006-01-31 | 2010-07-13 | Ethicon Endo-Surgery, Inc. | Endoscopic surgical instrument with a handle that can articulate with respect to the shaft |
| US20120292367A1 (en) | 2006-01-31 | 2012-11-22 | Ethicon Endo-Surgery, Inc. | Robotically-controlled end effector |
| US8992422B2 (en) | 2006-03-23 | 2015-03-31 | Ethicon Endo-Surgery, Inc. | Robotically-controlled endoscopic accessory channel |
| US20070225562A1 (en) | 2006-03-23 | 2007-09-27 | Ethicon Endo-Surgery, Inc. | Articulating endoscopic accessory channel |
| CN104688327B (zh) * | 2006-06-13 | 2017-06-09 | 直观外科手术操作公司 | 微创手术系统 |
| US8322455B2 (en) | 2006-06-27 | 2012-12-04 | Ethicon Endo-Surgery, Inc. | Manually driven surgical cutting and fastening instrument |
| RU2445934C2 (ru) | 2006-09-14 | 2012-03-27 | Конинклейке Филипс Электроникс Н.В. | Конфигурирование активной канюли для минимально инвазивной хирургии |
| US10568652B2 (en) | 2006-09-29 | 2020-02-25 | Ethicon Llc | Surgical staples having attached drivers of different heights and stapling instruments for deploying the same |
| US10130359B2 (en) | 2006-09-29 | 2018-11-20 | Ethicon Llc | Method for forming a staple |
| US11980366B2 (en) | 2006-10-03 | 2024-05-14 | Cilag Gmbh International | Surgical instrument |
| US9232959B2 (en) | 2007-01-02 | 2016-01-12 | Aquabeam, Llc | Multi fluid tissue resection methods and devices |
| US12290277B2 (en) | 2007-01-02 | 2025-05-06 | Aquabeam, Llc | Tissue resection with pressure sensing |
| US8652120B2 (en) | 2007-01-10 | 2014-02-18 | Ethicon Endo-Surgery, Inc. | Surgical instrument with wireless communication between control unit and sensor transponders |
| US8684253B2 (en) | 2007-01-10 | 2014-04-01 | Ethicon Endo-Surgery, Inc. | Surgical instrument with wireless communication between a control unit of a robotic system and remote sensor |
| US11291441B2 (en) | 2007-01-10 | 2022-04-05 | Cilag Gmbh International | Surgical instrument with wireless communication between control unit and remote sensor |
| US8840603B2 (en) | 2007-01-10 | 2014-09-23 | Ethicon Endo-Surgery, Inc. | Surgical instrument with wireless communication between control unit and sensor transponders |
| US8827133B2 (en) | 2007-01-11 | 2014-09-09 | Ethicon Endo-Surgery, Inc. | Surgical stapling device having supports for a flexible drive mechanism |
| US11039836B2 (en) | 2007-01-11 | 2021-06-22 | Cilag Gmbh International | Staple cartridge for use with a surgical stapling instrument |
| US7673782B2 (en) | 2007-03-15 | 2010-03-09 | Ethicon Endo-Surgery, Inc. | Surgical stapling instrument having a releasable buttress material |
| US8893946B2 (en) | 2007-03-28 | 2014-11-25 | Ethicon Endo-Surgery, Inc. | Laparoscopic tissue thickness and clamp load measuring devices |
| US9387124B2 (en) | 2007-04-19 | 2016-07-12 | Tusker Medical, Inc. | Disposable iontophoresis system and tympanic membrane pain inhibition method |
| US11564682B2 (en) | 2007-06-04 | 2023-01-31 | Cilag Gmbh International | Surgical stapler device |
| US8931682B2 (en) | 2007-06-04 | 2015-01-13 | Ethicon Endo-Surgery, Inc. | Robotically-controlled shaft based rotary drive systems for surgical instruments |
| US8408439B2 (en) | 2007-06-22 | 2013-04-02 | Ethicon Endo-Surgery, Inc. | Surgical stapling instrument with an articulatable end effector |
| US7753245B2 (en) | 2007-06-22 | 2010-07-13 | Ethicon Endo-Surgery, Inc. | Surgical stapling instruments |
| US11849941B2 (en) | 2007-06-29 | 2023-12-26 | Cilag Gmbh International | Staple cartridge having staple cavities extending at a transverse angle relative to a longitudinal cartridge axis |
| KR101634983B1 (ko) * | 2008-01-07 | 2016-07-01 | 살루타리스 메디컬 디바이스즈, 인코퍼레이티드 | 눈의 후부에 대한 방사선의 전달을 위한 외안의 최소한의 수술 방법 및 장치 |
| US8561870B2 (en) | 2008-02-13 | 2013-10-22 | Ethicon Endo-Surgery, Inc. | Surgical stapling instrument |
| US8573465B2 (en) | 2008-02-14 | 2013-11-05 | Ethicon Endo-Surgery, Inc. | Robotically-controlled surgical end effector system with rotary actuated closure systems |
| US8758391B2 (en) | 2008-02-14 | 2014-06-24 | Ethicon Endo-Surgery, Inc. | Interchangeable tools for surgical instruments |
| US7866527B2 (en) | 2008-02-14 | 2011-01-11 | Ethicon Endo-Surgery, Inc. | Surgical stapling apparatus with interlockable firing system |
| BRPI0901282A2 (pt) | 2008-02-14 | 2009-11-17 | Ethicon Endo Surgery Inc | instrumento cirúrgico de corte e fixação dotado de eletrodos de rf |
| US11986183B2 (en) | 2008-02-14 | 2024-05-21 | Cilag Gmbh International | Surgical cutting and fastening instrument comprising a plurality of sensors to measure an electrical parameter |
| US8636736B2 (en) | 2008-02-14 | 2014-01-28 | Ethicon Endo-Surgery, Inc. | Motorized surgical cutting and fastening instrument |
| US8657174B2 (en) | 2008-02-14 | 2014-02-25 | Ethicon Endo-Surgery, Inc. | Motorized surgical cutting and fastening instrument having handle based power source |
| US7819298B2 (en) | 2008-02-14 | 2010-10-26 | Ethicon Endo-Surgery, Inc. | Surgical stapling apparatus with control features operable with one hand |
| US9179912B2 (en) | 2008-02-14 | 2015-11-10 | Ethicon Endo-Surgery, Inc. | Robotically-controlled motorized surgical cutting and fastening instrument |
| US20130153641A1 (en) | 2008-02-15 | 2013-06-20 | Ethicon Endo-Surgery, Inc. | Releasable layer of material and surgical end effector having the same |
| US20090206131A1 (en) | 2008-02-15 | 2009-08-20 | Ethicon Endo-Surgery, Inc. | End effector coupling arrangements for a surgical cutting and stapling instrument |
| US11272927B2 (en) | 2008-02-15 | 2022-03-15 | Cilag Gmbh International | Layer arrangements for surgical staple cartridges |
| JP5506702B2 (ja) | 2008-03-06 | 2014-05-28 | アクアビーム エルエルシー | 流体流れ内を伝達される光学エネルギーによる組織切除および焼灼 |
| US8096985B2 (en) | 2008-05-07 | 2012-01-17 | Guided Delivery Systems Inc. | Deflectable guide |
| EP2303157A1 (en) | 2008-06-25 | 2011-04-06 | Koninklijke Philips Electronics N.V. | Nested cannulae for minimally invasive surgery |
| US20110166514A1 (en) * | 2008-09-16 | 2011-07-07 | Koninklijke Philips Electronics N.V. | Automated system for the controlled deployment of nested cannula |
| US7954686B2 (en) | 2008-09-19 | 2011-06-07 | Ethicon Endo-Surgery, Inc. | Surgical stapler with apparatus for adjusting staple height |
| PL3476312T3 (pl) | 2008-09-19 | 2024-03-11 | Ethicon Llc | Stapler chirurgiczny z urządzeniem do dopasowania wysokości zszywek |
| US8210411B2 (en) | 2008-09-23 | 2012-07-03 | Ethicon Endo-Surgery, Inc. | Motor-driven surgical cutting instrument |
| US11648005B2 (en) | 2008-09-23 | 2023-05-16 | Cilag Gmbh International | Robotically-controlled motorized surgical instrument with an end effector |
| US9005230B2 (en) | 2008-09-23 | 2015-04-14 | Ethicon Endo-Surgery, Inc. | Motorized surgical instrument |
| US9386983B2 (en) | 2008-09-23 | 2016-07-12 | Ethicon Endo-Surgery, Llc | Robotically-controlled motorized surgical instrument |
| US8608045B2 (en) | 2008-10-10 | 2013-12-17 | Ethicon Endo-Sugery, Inc. | Powered surgical cutting and stapling apparatus with manually retractable firing system |
| RU2550659C2 (ru) * | 2008-10-17 | 2015-05-10 | Конинклейке Филипс Электроникс, Н.В. | Телескопическая канюля с блокировкой |
| US20100121148A1 (en) * | 2008-11-11 | 2010-05-13 | Intuitive Surgical, Inc. | Method and system for steerable medical device path definition and following during insertion and retraction |
| US8568302B2 (en) | 2008-11-11 | 2013-10-29 | Intuitive Surgical Operations, Inc. | Method and system for steerable medical device path definition and following during insertion and retraction |
| RU2011130811A (ru) * | 2008-12-23 | 2013-01-27 | Конинклейке Филипс Электроникс Н.В. | Конфигурация телескопической канюли для применения с эндоскопом |
| US20110270040A1 (en) * | 2008-12-29 | 2011-11-03 | Koninklijke Philips Electronics N.V. | Planning for curvature interactions, multiple radii of curvature and adaptive neighborhoods |
| US20110295199A1 (en) * | 2008-12-29 | 2011-12-01 | Koninklijke Philips Electronics N.V. | Planning and assembly of compensating concentric cannulas |
| WO2010085456A1 (en) | 2009-01-20 | 2010-07-29 | Guided Delivery Systems Inc. | Anchor deployment devices and related methods |
| WO2010085457A1 (en) * | 2009-01-20 | 2010-07-29 | Guided Delivery Systems Inc. | Diagnostic catheters, guide catheters, visualization devices and chord manipulation devices, and related kits and methods |
| US8517239B2 (en) | 2009-02-05 | 2013-08-27 | Ethicon Endo-Surgery, Inc. | Surgical stapling instrument comprising a magnetic element driver |
| US8444036B2 (en) | 2009-02-06 | 2013-05-21 | Ethicon Endo-Surgery, Inc. | Motor driven surgical fastener device with mechanisms for adjusting a tissue gap within the end effector |
| BRPI1008667A2 (pt) | 2009-02-06 | 2016-03-08 | Ethicom Endo Surgery Inc | aperfeiçoamento do grampeador cirúrgico acionado |
| JP6118110B2 (ja) * | 2009-03-31 | 2017-04-19 | コーニンクレッカ フィリップス エヌ ヴェKoninklijke Philips N.V. | 入れ子状カニューレに関するらせん状連続的屈曲チューブ |
| JP2012525190A (ja) | 2009-04-29 | 2012-10-22 | コーニンクレッカ フィリップス エレクトロニクス エヌ ヴィ | 単眼の内視鏡画像からのリアルタイム深度推定 |
| US9539146B2 (en) | 2009-07-15 | 2017-01-10 | Tusker Medical, Inc. | Trigger assembly for tympanostomy tube delivery device |
| US9770366B2 (en) | 2009-07-15 | 2017-09-26 | Tusker Medical, Inc. | Tympanic membrane pressure equalization tube delivery system |
| US8659977B2 (en) * | 2009-10-28 | 2014-02-25 | University Of Southern California | Acoustic signal generation system using moving reflecting surface |
| US8220688B2 (en) | 2009-12-24 | 2012-07-17 | Ethicon Endo-Surgery, Inc. | Motor-driven surgical cutting instrument with electric actuator directional control assembly |
| US8851354B2 (en) | 2009-12-24 | 2014-10-07 | Ethicon Endo-Surgery, Inc. | Surgical cutting instrument that analyzes tissue thickness |
| US8608046B2 (en) | 2010-01-07 | 2013-12-17 | Ethicon Endo-Surgery, Inc. | Test device for a surgical tool |
| US8343045B2 (en) * | 2010-04-05 | 2013-01-01 | Intuitive Surgical Operations, Inc. | Curved cannula |
| US8783543B2 (en) | 2010-07-30 | 2014-07-22 | Ethicon Endo-Surgery, Inc. | Tissue acquisition arrangements and methods for surgical stapling devices |
| JP5905885B2 (ja) * | 2010-08-13 | 2016-04-20 | キャスアールエックス リミテッドCathrx Ltd | 偏向サイズ調整機能を備えたカテーテルアセンブリ |
| US8360296B2 (en) | 2010-09-09 | 2013-01-29 | Ethicon Endo-Surgery, Inc. | Surgical stapling head assembly with firing lockout for a surgical stapler |
| US8632525B2 (en) | 2010-09-17 | 2014-01-21 | Ethicon Endo-Surgery, Inc. | Power control arrangements for surgical instruments and batteries |
| US9289212B2 (en) | 2010-09-17 | 2016-03-22 | Ethicon Endo-Surgery, Inc. | Surgical instruments and batteries for surgical instruments |
| US8733613B2 (en) | 2010-09-29 | 2014-05-27 | Ethicon Endo-Surgery, Inc. | Staple cartridge |
| US9480476B2 (en) | 2010-09-30 | 2016-11-01 | Ethicon Endo-Surgery, Llc | Tissue thickness compensator comprising resilient members |
| US8746535B2 (en) | 2010-09-30 | 2014-06-10 | Ethicon Endo-Surgery, Inc. | Tissue thickness compensator comprising detachable portions |
| US10945731B2 (en) | 2010-09-30 | 2021-03-16 | Ethicon Llc | Tissue thickness compensator comprising controlled release and expansion |
| US9220501B2 (en) | 2010-09-30 | 2015-12-29 | Ethicon Endo-Surgery, Inc. | Tissue thickness compensators |
| US9301753B2 (en) | 2010-09-30 | 2016-04-05 | Ethicon Endo-Surgery, Llc | Expandable tissue thickness compensator |
| US9629814B2 (en) | 2010-09-30 | 2017-04-25 | Ethicon Endo-Surgery, Llc | Tissue thickness compensator configured to redistribute compressive forces |
| US9332974B2 (en) | 2010-09-30 | 2016-05-10 | Ethicon Endo-Surgery, Llc | Layered tissue thickness compensator |
| US9307989B2 (en) | 2012-03-28 | 2016-04-12 | Ethicon Endo-Surgery, Llc | Tissue stapler having a thickness compensator incorportating a hydrophobic agent |
| US10405854B2 (en) | 2010-09-30 | 2019-09-10 | Ethicon Llc | Surgical stapling cartridge with layer retention features |
| US12213666B2 (en) | 2010-09-30 | 2025-02-04 | Cilag Gmbh International | Tissue thickness compensator comprising layers |
| US9386988B2 (en) | 2010-09-30 | 2016-07-12 | Ethicon End-Surgery, LLC | Retainer assembly including a tissue thickness compensator |
| US9314246B2 (en) | 2010-09-30 | 2016-04-19 | Ethicon Endo-Surgery, Llc | Tissue stapler having a thickness compensator incorporating an anti-inflammatory agent |
| US11298125B2 (en) | 2010-09-30 | 2022-04-12 | Cilag Gmbh International | Tissue stapler having a thickness compensator |
| US11925354B2 (en) | 2010-09-30 | 2024-03-12 | Cilag Gmbh International | Staple cartridge comprising staples positioned within a compressible portion thereof |
| US9232941B2 (en) | 2010-09-30 | 2016-01-12 | Ethicon Endo-Surgery, Inc. | Tissue thickness compensator comprising a reservoir |
| AU2011308701B2 (en) | 2010-09-30 | 2013-11-14 | Ethicon Endo-Surgery, Inc. | Fastener system comprising a retention matrix and an alignment matrix |
| US9839420B2 (en) | 2010-09-30 | 2017-12-12 | Ethicon Llc | Tissue thickness compensator comprising at least one medicament |
| US9364233B2 (en) | 2010-09-30 | 2016-06-14 | Ethicon Endo-Surgery, Llc | Tissue thickness compensators for circular surgical staplers |
| US11812965B2 (en) | 2010-09-30 | 2023-11-14 | Cilag Gmbh International | Layer of material for a surgical end effector |
| US9055941B2 (en) | 2011-09-23 | 2015-06-16 | Ethicon Endo-Surgery, Inc. | Staple cartridge including collapsible deck |
| US8695866B2 (en) | 2010-10-01 | 2014-04-15 | Ethicon Endo-Surgery, Inc. | Surgical instrument having a power control circuit |
| JP5585369B2 (ja) * | 2010-10-12 | 2014-09-10 | セイコーエプソン株式会社 | 流体噴射装置、および医療機器 |
| US20120091307A1 (en) * | 2010-10-13 | 2012-04-19 | Debra Haynes | Stand and method for hands free reading and viewing |
| US9060765B2 (en) | 2010-11-08 | 2015-06-23 | Bovie Medical Corporation | Electrosurgical apparatus with retractable blade |
| US8827903B2 (en) | 2011-03-14 | 2014-09-09 | Ethicon Endo-Surgery, Inc. | Modular tool heads for use with circular surgical instruments |
| BR112013027794B1 (pt) | 2011-04-29 | 2020-12-15 | Ethicon Endo-Surgery, Inc | Conjunto de cartucho de grampos |
| US11207064B2 (en) | 2011-05-27 | 2021-12-28 | Cilag Gmbh International | Automated end effector component reloading system for use with a robotic system |
| US8486009B2 (en) * | 2011-06-20 | 2013-07-16 | Hue-Teh Shih | Systems and methods for steering catheters |
| US9050084B2 (en) | 2011-09-23 | 2015-06-09 | Ethicon Endo-Surgery, Inc. | Staple cartridge including collapsible deck arrangement |
| FR2981260B1 (fr) * | 2011-10-18 | 2014-12-12 | Univ Grenoble 1 | Dispositif de guidage d'une aiguille medicale |
| WO2013074970A1 (en) | 2011-11-16 | 2013-05-23 | Vanderbilt University | Motive device for use in magnetically-sensitive environments |
| US9504604B2 (en) | 2011-12-16 | 2016-11-29 | Auris Surgical Robotics, Inc. | Lithotripsy eye treatment |
| EP2809249B1 (en) | 2012-02-03 | 2018-12-26 | Intuitive Surgical Operations, Inc. | Steerable flexible needle with embedded shape sensing |
| US20130218005A1 (en) * | 2012-02-08 | 2013-08-22 | University Of Maryland, Baltimore | Minimally invasive neurosurgical intracranial robot system and method |
| US9044230B2 (en) | 2012-02-13 | 2015-06-02 | Ethicon Endo-Surgery, Inc. | Surgical cutting and fastening instrument with apparatus for determining cartridge and firing motion status |
| US8746075B2 (en) | 2012-02-16 | 2014-06-10 | 7-Sigma, Inc. | Flexible electrically conductive nanotube sensor for elastomeric devices |
| KR101391405B1 (ko) | 2012-02-24 | 2014-05-02 | 유-충 창 | 바늘 유닛 |
| CN104203078B (zh) | 2012-02-29 | 2018-04-20 | 普罗赛普特生物机器人公司 | 自动化图像引导的组织切除和处理 |
| MX353040B (es) | 2012-03-28 | 2017-12-18 | Ethicon Endo Surgery Inc | Unidad retenedora que incluye un compensador de grosor de tejido. |
| JP6105041B2 (ja) | 2012-03-28 | 2017-03-29 | エシコン・エンド−サージェリィ・インコーポレイテッドEthicon Endo−Surgery,Inc. | 低圧環境を画定するカプセルを含む組織厚コンペンセーター |
| RU2014143258A (ru) | 2012-03-28 | 2016-05-20 | Этикон Эндо-Серджери, Инк. | Компенсатор толщины ткани, содержащий множество слоев |
| CN104203131A (zh) * | 2012-03-30 | 2014-12-10 | 皇家飞利浦有限公司 | 嵌套套管起动器对准 |
| US20150051576A1 (en) * | 2012-03-30 | 2015-02-19 | Koninklijke Philips N.V. | Nested cannula tips |
| US10383765B2 (en) | 2012-04-24 | 2019-08-20 | Auris Health, Inc. | Apparatus and method for a global coordinate system for use in robotic surgery |
| US9101358B2 (en) | 2012-06-15 | 2015-08-11 | Ethicon Endo-Surgery, Inc. | Articulatable surgical instrument comprising a firing drive |
| WO2013192598A1 (en) * | 2012-06-21 | 2013-12-27 | Excelsius Surgical, L.L.C. | Surgical robot platform |
| US20140001231A1 (en) | 2012-06-28 | 2014-01-02 | Ethicon Endo-Surgery, Inc. | Firing system lockout arrangements for surgical instruments |
| CN104487005B (zh) | 2012-06-28 | 2017-09-08 | 伊西康内外科公司 | 空夹仓闭锁件 |
| US20140005678A1 (en) | 2012-06-28 | 2014-01-02 | Ethicon Endo-Surgery, Inc. | Rotary drive arrangements for surgical instruments |
| US9649111B2 (en) | 2012-06-28 | 2017-05-16 | Ethicon Endo-Surgery, Llc | Replaceable clip cartridge for a clip applier |
| US20140005718A1 (en) | 2012-06-28 | 2014-01-02 | Ethicon Endo-Surgery, Inc. | Multi-functional powered surgical device with external dissection features |
| US12383267B2 (en) | 2012-06-28 | 2025-08-12 | Cilag Gmbh International | Robotically powered surgical device with manually-actuatable reversing system |
| US11278284B2 (en) | 2012-06-28 | 2022-03-22 | Cilag Gmbh International | Rotary drive arrangements for surgical instruments |
| US9289256B2 (en) | 2012-06-28 | 2016-03-22 | Ethicon Endo-Surgery, Llc | Surgical end effectors having angled tissue-contacting surfaces |
| BR112014032776B1 (pt) | 2012-06-28 | 2021-09-08 | Ethicon Endo-Surgery, Inc | Sistema de instrumento cirúrgico e kit cirúrgico para uso com um sistema de instrumento cirúrgico |
| US9700310B2 (en) | 2013-08-23 | 2017-07-11 | Ethicon Llc | Firing member retraction devices for powered surgical instruments |
| US9386985B2 (en) | 2012-10-15 | 2016-07-12 | Ethicon Endo-Surgery, Llc | Surgical cutting instrument |
| US10258225B2 (en) | 2012-11-07 | 2019-04-16 | 3Nt Medical Ltd. | Paranasal sinus access system |
| US10231867B2 (en) | 2013-01-18 | 2019-03-19 | Auris Health, Inc. | Method, apparatus and system for a water jet |
| US9386984B2 (en) | 2013-02-08 | 2016-07-12 | Ethicon Endo-Surgery, Llc | Staple cartridge comprising a releasable cover |
| MX368026B (es) | 2013-03-01 | 2019-09-12 | Ethicon Endo Surgery Inc | Instrumento quirúrgico articulable con vías conductoras para la comunicación de la señal. |
| US20140249557A1 (en) | 2013-03-01 | 2014-09-04 | Ethicon Endo-Surgery, Inc. | Thumbwheel switch arrangements for surgical instruments |
| MX364729B (es) | 2013-03-01 | 2019-05-06 | Ethicon Endo Surgery Inc | Instrumento quirúrgico con una parada suave. |
| US10149720B2 (en) | 2013-03-08 | 2018-12-11 | Auris Health, Inc. | Method, apparatus, and a system for facilitating bending of an instrument in a surgical or medical robotic environment |
| US10080576B2 (en) | 2013-03-08 | 2018-09-25 | Auris Health, Inc. | Method, apparatus, and a system for facilitating bending of an instrument in a surgical or medical robotic environment |
| US9867635B2 (en) | 2013-03-08 | 2018-01-16 | Auris Surgical Robotics, Inc. | Method, apparatus and system for a water jet |
| US20140261453A1 (en) * | 2013-03-12 | 2014-09-18 | Hansen Medical, Inc. | Noncontact encoder for measuring catheter insertion |
| US20140263552A1 (en) | 2013-03-13 | 2014-09-18 | Ethicon Endo-Surgery, Inc. | Staple cartridge tissue thickness sensor system |
| AU2013381815B2 (en) * | 2013-03-14 | 2017-04-13 | 7-Sigma, Inc. | Responsive device with sensors |
| US9629629B2 (en) | 2013-03-14 | 2017-04-25 | Ethicon Endo-Surgey, LLC | Control systems for surgical instruments |
| US9888919B2 (en) | 2013-03-14 | 2018-02-13 | Ethicon Llc | Method and system for operating a surgical instrument |
| US9681891B2 (en) | 2013-03-14 | 2017-06-20 | Tusker Medical, Inc. | Tympanostomy tube delivery device with cutting dilator |
| US9320652B2 (en) | 2013-03-14 | 2016-04-26 | Tusker Medical, Inc. | Features to improve and sense tympanic membrane apposition by tympanostomy tube delivery instrument |
| US9572577B2 (en) | 2013-03-27 | 2017-02-21 | Ethicon Endo-Surgery, Llc | Fastener cartridge comprising a tissue thickness compensator including openings therein |
| US9332984B2 (en) | 2013-03-27 | 2016-05-10 | Ethicon Endo-Surgery, Llc | Fastener cartridge assemblies |
| US9795384B2 (en) | 2013-03-27 | 2017-10-24 | Ethicon Llc | Fastener cartridge comprising a tissue thickness compensator and a gap setting element |
| BR112015026109B1 (pt) | 2013-04-16 | 2022-02-22 | Ethicon Endo-Surgery, Inc | Instrumento cirúrgico |
| US9649110B2 (en) | 2013-04-16 | 2017-05-16 | Ethicon Llc | Surgical instrument comprising a closing drive and a firing drive operated from the same rotatable output |
| US9574644B2 (en) | 2013-05-30 | 2017-02-21 | Ethicon Endo-Surgery, Llc | Power module for use with a surgical instrument |
| WO2014201165A1 (en) | 2013-06-11 | 2014-12-18 | Auris Surgical Robotics, Inc. | System for robotic assisted cataract surgery |
| JP6274630B2 (ja) * | 2013-06-19 | 2018-02-07 | タイタン メディカル インコーポレイテッドTitan Medical Inc. | 多関節器具位置決め装置およびそれを採用するシステム |
| KR101506932B1 (ko) | 2013-07-29 | 2015-04-07 | 한국과학기술연구원 | 방향전환이 가능한 엔드 이펙터를 구비하는 튜브 삽입장치 |
| US10426661B2 (en) | 2013-08-13 | 2019-10-01 | Auris Health, Inc. | Method and apparatus for laser assisted cataract surgery |
| JP6416260B2 (ja) | 2013-08-23 | 2018-10-31 | エシコン エルエルシー | 動力付き外科用器具のための発射部材後退装置 |
| CN105939647B (zh) | 2013-10-24 | 2020-01-21 | 奥瑞斯健康公司 | 机器人辅助腔内外科手术系统及相关方法 |
| US9980785B2 (en) | 2013-10-24 | 2018-05-29 | Auris Health, Inc. | Instrument device manipulator with surgical tool de-articulation |
| KR101535520B1 (ko) * | 2013-10-31 | 2015-07-09 | 한국과학기술연구원 | 초탄성 특성이 개선된 선재 및 그를 이용한 튜브 연속체 로봇 |
| WO2015073943A1 (en) | 2013-11-18 | 2015-05-21 | Vanderbilt University | System and apparatus for performing transforminal therapy |
| US10688284B2 (en) | 2013-11-22 | 2020-06-23 | Massachusetts Institute Of Technology | Steering techniques for surgical instruments |
| US9839428B2 (en) | 2013-12-23 | 2017-12-12 | Ethicon Llc | Surgical cutting and stapling instruments with independent jaw control features |
| US9681870B2 (en) | 2013-12-23 | 2017-06-20 | Ethicon Llc | Articulatable surgical instruments with separate and distinct closing and firing systems |
| US9687232B2 (en) | 2013-12-23 | 2017-06-27 | Ethicon Llc | Surgical staples |
| US9642620B2 (en) | 2013-12-23 | 2017-05-09 | Ethicon Endo-Surgery, Llc | Surgical cutting and stapling instruments with articulatable end effectors |
| US9724092B2 (en) | 2013-12-23 | 2017-08-08 | Ethicon Llc | Modular surgical instruments |
| US20150173756A1 (en) | 2013-12-23 | 2015-06-25 | Ethicon Endo-Surgery, Inc. | Surgical cutting and stapling methods |
| KR101525457B1 (ko) | 2014-02-10 | 2015-06-03 | 한국과학기술연구원 | 고곡률 관절 구조체를 구비한 내시경 로봇 |
| US9962161B2 (en) | 2014-02-12 | 2018-05-08 | Ethicon Llc | Deliverable surgical instrument |
| US20140166724A1 (en) | 2014-02-24 | 2014-06-19 | Ethicon Endo-Surgery, Inc. | Staple cartridge including a barbed staple |
| JP6462004B2 (ja) | 2014-02-24 | 2019-01-30 | エシコン エルエルシー | 発射部材ロックアウトを備える締結システム |
| US9913642B2 (en) | 2014-03-26 | 2018-03-13 | Ethicon Llc | Surgical instrument comprising a sensor system |
| US10004497B2 (en) | 2014-03-26 | 2018-06-26 | Ethicon Llc | Interface systems for use with surgical instruments |
| US12232723B2 (en) | 2014-03-26 | 2025-02-25 | Cilag Gmbh International | Systems and methods for controlling a segmented circuit |
| US9690362B2 (en) | 2014-03-26 | 2017-06-27 | Ethicon Llc | Surgical instrument control circuit having a safety processor |
| US9743929B2 (en) | 2014-03-26 | 2017-08-29 | Ethicon Llc | Modular powered surgical instrument with detachable shaft assemblies |
| BR112016021943B1 (pt) | 2014-03-26 | 2022-06-14 | Ethicon Endo-Surgery, Llc | Instrumento cirúrgico para uso por um operador em um procedimento cirúrgico |
| JP6636452B2 (ja) | 2014-04-16 | 2020-01-29 | エシコン エルエルシーEthicon LLC | 異なる構成を有する延在部を含む締結具カートリッジ |
| US10426476B2 (en) | 2014-09-26 | 2019-10-01 | Ethicon Llc | Circular fastener cartridges for applying radially expandable fastener lines |
| US10561422B2 (en) | 2014-04-16 | 2020-02-18 | Ethicon Llc | Fastener cartridge comprising deployable tissue engaging members |
| US20150297225A1 (en) | 2014-04-16 | 2015-10-22 | Ethicon Endo-Surgery, Inc. | Fastener cartridges including extensions having different configurations |
| BR112016023825B1 (pt) | 2014-04-16 | 2022-08-02 | Ethicon Endo-Surgery, Llc | Cartucho de grampos para uso com um grampeador cirúrgico e cartucho de grampos para uso com um instrumento cirúrgico |
| BR112016023807B1 (pt) | 2014-04-16 | 2022-07-12 | Ethicon Endo-Surgery, Llc | Conjunto de cartucho de prendedores para uso com um instrumento cirúrgico |
| US10045781B2 (en) | 2014-06-13 | 2018-08-14 | Ethicon Llc | Closure lockout systems for surgical instruments |
| US9788910B2 (en) | 2014-07-01 | 2017-10-17 | Auris Surgical Robotics, Inc. | Instrument-mounted tension sensing mechanism for robotically-driven medical instruments |
| US10792464B2 (en) | 2014-07-01 | 2020-10-06 | Auris Health, Inc. | Tool and method for using surgical endoscope with spiral lumens |
| KR101667933B1 (ko) * | 2014-07-18 | 2016-10-21 | 한국과학기술연구원 | 선형 제어가 가능한 튜브체를 구비하는 튜브 연속체 로봇 |
| US20160038341A1 (en) | 2014-08-08 | 2016-02-11 | Acclarent, Inc. | Tympanostomy tube delivery device with elastomeric brake |
| US10195086B2 (en) * | 2014-08-11 | 2019-02-05 | Tusker Medical, Inc. | Tympanostomy tube delivery device with rotatable |
| US9833359B2 (en) | 2014-08-12 | 2017-12-05 | Tusker Medical, Inc. | Tympanostomy tube delivery device with cutter force clutch |
| US9833360B2 (en) | 2014-08-12 | 2017-12-05 | Tusker Medical, Inc. | Tympanostomy tube delivery device with replaceable shaft portion |
| SI3188682T1 (sl) * | 2014-09-04 | 2021-03-31 | Memic Innovative Surgery Ltd. | Krmiljenje naprave, vključno z mehanskimi rokami |
| US10111679B2 (en) | 2014-09-05 | 2018-10-30 | Ethicon Llc | Circuitry and sensors for powered medical device |
| BR112017004361B1 (pt) | 2014-09-05 | 2023-04-11 | Ethicon Llc | Sistema eletrônico para um instrumento cirúrgico |
| US11311294B2 (en) | 2014-09-05 | 2022-04-26 | Cilag Gmbh International | Powered medical device including measurement of closure state of jaws |
| US10105142B2 (en) | 2014-09-18 | 2018-10-23 | Ethicon Llc | Surgical stapler with plurality of cutting elements |
| DE102014113962B3 (de) | 2014-09-26 | 2015-12-10 | Gottfried Wilhelm Leibniz Universität Hannover | Arbeitsmechanismus |
| US11523821B2 (en) | 2014-09-26 | 2022-12-13 | Cilag Gmbh International | Method for creating a flexible staple line |
| MX380639B (es) | 2014-09-26 | 2025-03-12 | Ethicon Llc | Refuerzos de grapas quirúrgicas y materiales auxiliares. |
| KR20170076690A (ko) * | 2014-09-30 | 2017-07-04 | 메사추세츠 인스티튜트 오브 테크놀로지 | 최소 침습 수술용 기구 |
| US10076325B2 (en) | 2014-10-13 | 2018-09-18 | Ethicon Llc | Surgical stapling apparatus comprising a tissue stop |
| US9924944B2 (en) | 2014-10-16 | 2018-03-27 | Ethicon Llc | Staple cartridge comprising an adjunct material |
| US11141153B2 (en) | 2014-10-29 | 2021-10-12 | Cilag Gmbh International | Staple cartridges comprising driver arrangements |
| US10517594B2 (en) | 2014-10-29 | 2019-12-31 | Ethicon Llc | Cartridge assemblies for surgical staplers |
| US9844376B2 (en) | 2014-11-06 | 2017-12-19 | Ethicon Llc | Staple cartridge comprising a releasable adjunct material |
| US10736636B2 (en) | 2014-12-10 | 2020-08-11 | Ethicon Llc | Articulatable surgical instrument system |
| BR112017012996B1 (pt) | 2014-12-18 | 2022-11-08 | Ethicon Llc | Instrumento cirúrgico com uma bigorna que é seletivamente móvel sobre um eixo geométrico imóvel distinto em relação a um cartucho de grampos |
| US9968355B2 (en) | 2014-12-18 | 2018-05-15 | Ethicon Llc | Surgical instruments with articulatable end effectors and improved firing beam support arrangements |
| US10188385B2 (en) | 2014-12-18 | 2019-01-29 | Ethicon Llc | Surgical instrument system comprising lockable systems |
| US9844374B2 (en) | 2014-12-18 | 2017-12-19 | Ethicon Llc | Surgical instrument systems comprising an articulatable end effector and means for adjusting the firing stroke of a firing member |
| US9987000B2 (en) | 2014-12-18 | 2018-06-05 | Ethicon Llc | Surgical instrument assembly comprising a flexible articulation system |
| US10117649B2 (en) | 2014-12-18 | 2018-11-06 | Ethicon Llc | Surgical instrument assembly comprising a lockable articulation system |
| US10085748B2 (en) | 2014-12-18 | 2018-10-02 | Ethicon Llc | Locking arrangements for detachable shaft assemblies with articulatable surgical end effectors |
| US9844375B2 (en) | 2014-12-18 | 2017-12-19 | Ethicon Llc | Drive arrangements for articulatable surgical instruments |
| US11154301B2 (en) | 2015-02-27 | 2021-10-26 | Cilag Gmbh International | Modular stapling assembly |
| US10159483B2 (en) | 2015-02-27 | 2018-12-25 | Ethicon Llc | Surgical apparatus configured to track an end-of-life parameter |
| US9993258B2 (en) | 2015-02-27 | 2018-06-12 | Ethicon Llc | Adaptable surgical instrument handle |
| US10180463B2 (en) | 2015-02-27 | 2019-01-15 | Ethicon Llc | Surgical apparatus configured to assess whether a performance parameter of the surgical apparatus is within an acceptable performance band |
| WO2016141358A1 (en) | 2015-03-05 | 2016-09-09 | Guided Delivery Systems Inc. | Devices and methods of visualizing and determining depth of penetration in cardiac tissue |
| US9993248B2 (en) | 2015-03-06 | 2018-06-12 | Ethicon Endo-Surgery, Llc | Smart sensors with local signal processing |
| US10441279B2 (en) | 2015-03-06 | 2019-10-15 | Ethicon Llc | Multiple level thresholds to modify operation of powered surgical instruments |
| US9808246B2 (en) | 2015-03-06 | 2017-11-07 | Ethicon Endo-Surgery, Llc | Method of operating a powered surgical instrument |
| US9924961B2 (en) | 2015-03-06 | 2018-03-27 | Ethicon Endo-Surgery, Llc | Interactive feedback system for powered surgical instruments |
| JP2020121162A (ja) | 2015-03-06 | 2020-08-13 | エシコン エルエルシーEthicon LLC | 測定の安定性要素、クリープ要素、及び粘弾性要素を決定するためのセンサデータの時間依存性評価 |
| US10052044B2 (en) | 2015-03-06 | 2018-08-21 | Ethicon Llc | Time dependent evaluation of sensor data to determine stability, creep, and viscoelastic elements of measures |
| US9895148B2 (en) | 2015-03-06 | 2018-02-20 | Ethicon Endo-Surgery, Llc | Monitoring speed control and precision incrementing of motor for powered surgical instruments |
| US10687806B2 (en) | 2015-03-06 | 2020-06-23 | Ethicon Llc | Adaptive tissue compression techniques to adjust closure rates for multiple tissue types |
| US10245033B2 (en) | 2015-03-06 | 2019-04-02 | Ethicon Llc | Surgical instrument comprising a lockable battery housing |
| US9901342B2 (en) | 2015-03-06 | 2018-02-27 | Ethicon Endo-Surgery, Llc | Signal and power communication system positioned on a rotatable shaft |
| US10045776B2 (en) | 2015-03-06 | 2018-08-14 | Ethicon Llc | Control techniques and sub-processor contained within modular shaft with select control processing from handle |
| US10617412B2 (en) | 2015-03-06 | 2020-04-14 | Ethicon Llc | System for detecting the mis-insertion of a staple cartridge into a surgical stapler |
| US10390825B2 (en) | 2015-03-31 | 2019-08-27 | Ethicon Llc | Surgical instrument with progressive rotary drive systems |
| WO2016191364A1 (en) * | 2015-05-22 | 2016-12-01 | The University Of North Carolina At Chapel Hill | Methods, systems, and computer readable media for controlling a concentric tube probe |
| US10405863B2 (en) | 2015-06-18 | 2019-09-10 | Ethicon Llc | Movable firing beam support arrangements for articulatable surgical instruments |
| KR101700885B1 (ko) | 2015-06-23 | 2017-02-01 | 한국과학기술연구원 | 복수의 튜브 연속체를 사용한 수술용 로봇 시스템 |
| US10835249B2 (en) | 2015-08-17 | 2020-11-17 | Ethicon Llc | Implantable layers for a surgical instrument |
| CN108348233B (zh) | 2015-08-26 | 2021-05-07 | 伊西康有限责任公司 | 用于允许改变钉特性并实现轻松仓加载的外科钉条 |
| BR112018003707B8 (pt) | 2015-08-26 | 2023-05-16 | Ethicon Llc | Conjunto de cartucho de grampos |
| MX2022009705A (es) | 2015-08-26 | 2022-11-07 | Ethicon Llc | Metodo para formar una grapa contra un yunque de un instrumento de engrapado quirurgico. |
| US10357251B2 (en) | 2015-08-26 | 2019-07-23 | Ethicon Llc | Surgical staples comprising hardness variations for improved fastening of tissue |
| MX2022006192A (es) | 2015-09-02 | 2022-06-16 | Ethicon Llc | Configuraciones de grapas quirurgicas con superficies de leva situadas entre porciones que soportan grapas quirurgicas. |
| US10172619B2 (en) | 2015-09-02 | 2019-01-08 | Ethicon Llc | Surgical staple driver arrays |
| EP3190942B1 (en) | 2015-09-04 | 2020-06-17 | Memic Innovative Surgery Ltd. | Actuation of a device comprising mechanical arms |
| AU2016321332B2 (en) | 2015-09-09 | 2020-10-08 | Auris Health, Inc. | Instrument device manipulator for a surgical robotics system |
| US10076326B2 (en) | 2015-09-23 | 2018-09-18 | Ethicon Llc | Surgical stapler having current mirror-based motor control |
| US10105139B2 (en) | 2015-09-23 | 2018-10-23 | Ethicon Llc | Surgical stapler having downstream current-based motor control |
| US10363036B2 (en) | 2015-09-23 | 2019-07-30 | Ethicon Llc | Surgical stapler having force-based motor control |
| US10327769B2 (en) | 2015-09-23 | 2019-06-25 | Ethicon Llc | Surgical stapler having motor control based on a drive system component |
| US10085751B2 (en) | 2015-09-23 | 2018-10-02 | Ethicon Llc | Surgical stapler having temperature-based motor control |
| US10238386B2 (en) | 2015-09-23 | 2019-03-26 | Ethicon Llc | Surgical stapler having motor control based on an electrical parameter related to a motor current |
| US10299878B2 (en) | 2015-09-25 | 2019-05-28 | Ethicon Llc | Implantable adjunct systems for determining adjunct skew |
| US11690623B2 (en) | 2015-09-30 | 2023-07-04 | Cilag Gmbh International | Method for applying an implantable layer to a fastener cartridge |
| US11890015B2 (en) | 2015-09-30 | 2024-02-06 | Cilag Gmbh International | Compressible adjunct with crossing spacer fibers |
| US10980539B2 (en) | 2015-09-30 | 2021-04-20 | Ethicon Llc | Implantable adjunct comprising bonded layers |
| US10736633B2 (en) | 2015-09-30 | 2020-08-11 | Ethicon Llc | Compressible adjunct with looping members |
| CA3012573C (en) * | 2015-10-06 | 2024-05-14 | Impossible Incorporated Llc | Snake-like robot |
| KR101783437B1 (ko) * | 2015-10-13 | 2017-09-29 | 한국과학기술연구원 | 내시경 로봇 |
| US10751123B2 (en) * | 2015-10-30 | 2020-08-25 | Washington University | Thermoablation probe |
| US10265068B2 (en) | 2015-12-30 | 2019-04-23 | Ethicon Llc | Surgical instruments with separable motors and motor control circuits |
| US10368865B2 (en) | 2015-12-30 | 2019-08-06 | Ethicon Llc | Mechanisms for compensating for drivetrain failure in powered surgical instruments |
| US10292704B2 (en) | 2015-12-30 | 2019-05-21 | Ethicon Llc | Mechanisms for compensating for battery pack failure in powered surgical instruments |
| US11344365B2 (en) * | 2016-01-05 | 2022-05-31 | Cardiofocus, Inc. | Ablation system with automated sweeping ablation energy element |
| BR112018016098B1 (pt) | 2016-02-09 | 2023-02-23 | Ethicon Llc | Instrumento cirúrgico |
| US10413291B2 (en) | 2016-02-09 | 2019-09-17 | Ethicon Llc | Surgical instrument articulation mechanism with slotted secondary constraint |
| US11213293B2 (en) | 2016-02-09 | 2022-01-04 | Cilag Gmbh International | Articulatable surgical instruments with single articulation link arrangements |
| WO2017139805A1 (en) * | 2016-02-11 | 2017-08-17 | Arrinex, Inc. | Method and device for image guided post-nasal nerve ablation |
| US10448948B2 (en) | 2016-02-12 | 2019-10-22 | Ethicon Llc | Mechanisms for compensating for drivetrain failure in powered surgical instruments |
| US11224426B2 (en) | 2016-02-12 | 2022-01-18 | Cilag Gmbh International | Mechanisms for compensating for drivetrain failure in powered surgical instruments |
| US10258331B2 (en) | 2016-02-12 | 2019-04-16 | Ethicon Llc | Mechanisms for compensating for drivetrain failure in powered surgical instruments |
| SI3219283T1 (sl) | 2016-03-09 | 2021-04-30 | Memic Innovative Surgery Ltd. | Modularna kirurška naprava, ki zajema mehanske roke |
| US10980607B2 (en) * | 2016-03-31 | 2021-04-20 | Koninklijke Philips N.V. | Image guidance of a steerable introducer for minimally invasive procedures |
| JP7010838B2 (ja) | 2016-04-01 | 2022-01-26 | エシコン エルエルシー | 外科用ステープル留め器具 |
| US10478190B2 (en) | 2016-04-01 | 2019-11-19 | Ethicon Llc | Surgical stapling system comprising a spent cartridge lockout |
| US11284890B2 (en) | 2016-04-01 | 2022-03-29 | Cilag Gmbh International | Circular stapling system comprising an incisable tissue support |
| US10285705B2 (en) | 2016-04-01 | 2019-05-14 | Ethicon Llc | Surgical stapling system comprising a grooved forming pocket |
| US10617413B2 (en) | 2016-04-01 | 2020-04-14 | Ethicon Llc | Closure system arrangements for surgical cutting and stapling devices with separate and distinct firing shafts |
| US10531874B2 (en) | 2016-04-01 | 2020-01-14 | Ethicon Llc | Surgical cutting and stapling end effector with anvil concentric drive member |
| US10456137B2 (en) | 2016-04-15 | 2019-10-29 | Ethicon Llc | Staple formation detection mechanisms |
| US10828028B2 (en) | 2016-04-15 | 2020-11-10 | Ethicon Llc | Surgical instrument with multiple program responses during a firing motion |
| US10426467B2 (en) | 2016-04-15 | 2019-10-01 | Ethicon Llc | Surgical instrument with detection sensors |
| US11607239B2 (en) | 2016-04-15 | 2023-03-21 | Cilag Gmbh International | Systems and methods for controlling a surgical stapling and cutting instrument |
| US10405859B2 (en) | 2016-04-15 | 2019-09-10 | Ethicon Llc | Surgical instrument with adjustable stop/start control during a firing motion |
| US10335145B2 (en) | 2016-04-15 | 2019-07-02 | Ethicon Llc | Modular surgical instrument with configurable operating mode |
| US10357247B2 (en) | 2016-04-15 | 2019-07-23 | Ethicon Llc | Surgical instrument with multiple program responses during a firing motion |
| US11179150B2 (en) | 2016-04-15 | 2021-11-23 | Cilag Gmbh International | Systems and methods for controlling a surgical stapling and cutting instrument |
| US10492783B2 (en) | 2016-04-15 | 2019-12-03 | Ethicon, Llc | Surgical instrument with improved stop/start control during a firing motion |
| US11317917B2 (en) | 2016-04-18 | 2022-05-03 | Cilag Gmbh International | Surgical stapling system comprising a lockable firing assembly |
| US20170296173A1 (en) | 2016-04-18 | 2017-10-19 | Ethicon Endo-Surgery, Llc | Method for operating a surgical instrument |
| US10433840B2 (en) | 2016-04-18 | 2019-10-08 | Ethicon Llc | Surgical instrument comprising a replaceable cartridge jaw |
| US11206972B2 (en) | 2016-06-06 | 2021-12-28 | 3Nt Medical Ltd. | Modular body cavity access system |
| USD850617S1 (en) | 2016-06-24 | 2019-06-04 | Ethicon Llc | Surgical fastener cartridge |
| CN109310431B (zh) | 2016-06-24 | 2022-03-04 | 伊西康有限责任公司 | 包括线材钉和冲压钉的钉仓 |
| USD826405S1 (en) | 2016-06-24 | 2018-08-21 | Ethicon Llc | Surgical fastener |
| USD847989S1 (en) | 2016-06-24 | 2019-05-07 | Ethicon Llc | Surgical fastener cartridge |
| US10675024B2 (en) | 2016-06-24 | 2020-06-09 | Ethicon Llc | Staple cartridge comprising overdriven staples |
| JP6980705B2 (ja) | 2016-06-24 | 2021-12-15 | エシコン エルエルシーEthicon LLC | ワイヤステープル及び打ち抜かれたステープルで使用するためのステープリングシステム |
| US20180042768A1 (en) * | 2016-08-10 | 2018-02-15 | Novartis Ag | Subretinal fluid drainage instruments, systems, and methods |
| US10500000B2 (en) | 2016-08-16 | 2019-12-10 | Ethicon Llc | Surgical tool with manual control of end effector jaws |
| CN107440704A (zh) * | 2016-11-26 | 2017-12-08 | 张霞玲 | 一种方向可调节的神经刺激探针 |
| US11419606B2 (en) | 2016-12-21 | 2022-08-23 | Cilag Gmbh International | Shaft assembly comprising a clutch configured to adapt the output of a rotary firing member to two different systems |
| US10603036B2 (en) | 2016-12-21 | 2020-03-31 | Ethicon Llc | Articulatable surgical instrument with independent pivotable linkage distal of an articulation lock |
| US11684367B2 (en) | 2016-12-21 | 2023-06-27 | Cilag Gmbh International | Stepped assembly having and end-of-life indicator |
| US10568625B2 (en) | 2016-12-21 | 2020-02-25 | Ethicon Llc | Staple cartridges and arrangements of staples and staple cavities therein |
| US10568624B2 (en) | 2016-12-21 | 2020-02-25 | Ethicon Llc | Surgical instruments with jaws that are pivotable about a fixed axis and include separate and distinct closure and firing systems |
| US10945727B2 (en) | 2016-12-21 | 2021-03-16 | Ethicon Llc | Staple cartridge with deformable driver retention features |
| MX2019007311A (es) | 2016-12-21 | 2019-11-18 | Ethicon Llc | Sistemas de engrapado quirurgico. |
| US10758229B2 (en) | 2016-12-21 | 2020-09-01 | Ethicon Llc | Surgical instrument comprising improved jaw control |
| US10675026B2 (en) | 2016-12-21 | 2020-06-09 | Ethicon Llc | Methods of stapling tissue |
| US11134942B2 (en) | 2016-12-21 | 2021-10-05 | Cilag Gmbh International | Surgical stapling instruments and staple-forming anvils |
| US10426471B2 (en) | 2016-12-21 | 2019-10-01 | Ethicon Llc | Surgical instrument with multiple failure response modes |
| US20180168625A1 (en) | 2016-12-21 | 2018-06-21 | Ethicon Endo-Surgery, Llc | Surgical stapling instruments with smart staple cartridges |
| US10856868B2 (en) | 2016-12-21 | 2020-12-08 | Ethicon Llc | Firing member pin configurations |
| US10993715B2 (en) | 2016-12-21 | 2021-05-04 | Ethicon Llc | Staple cartridge comprising staples with different clamping breadths |
| JP7010957B2 (ja) | 2016-12-21 | 2022-01-26 | エシコン エルエルシー | ロックアウトを備えるシャフトアセンブリ |
| US20180168615A1 (en) | 2016-12-21 | 2018-06-21 | Ethicon Endo-Surgery, Llc | Method of deforming staples from two different types of staple cartridges with the same surgical stapling instrument |
| JP7010956B2 (ja) | 2016-12-21 | 2022-01-26 | エシコン エルエルシー | 組織をステープル留めする方法 |
| US10588630B2 (en) | 2016-12-21 | 2020-03-17 | Ethicon Llc | Surgical tool assemblies with closure stroke reduction features |
| US10639035B2 (en) | 2016-12-21 | 2020-05-05 | Ethicon Llc | Surgical stapling instruments and replaceable tool assemblies thereof |
| CN110114014B (zh) | 2016-12-21 | 2022-08-09 | 爱惜康有限责任公司 | 包括端部执行器闭锁件和击发组件闭锁件的外科器械系统 |
| US10918385B2 (en) | 2016-12-21 | 2021-02-16 | Ethicon Llc | Surgical system comprising a firing member rotatable into an articulation state to articulate an end effector of the surgical system |
| US10537324B2 (en) | 2016-12-21 | 2020-01-21 | Ethicon Llc | Stepped staple cartridge with asymmetrical staples |
| US10687810B2 (en) | 2016-12-21 | 2020-06-23 | Ethicon Llc | Stepped staple cartridge with tissue retention and gap setting features |
| US10682138B2 (en) | 2016-12-21 | 2020-06-16 | Ethicon Llc | Bilaterally asymmetric staple forming pocket pairs |
| CN110114003A (zh) | 2016-12-21 | 2019-08-09 | 爱惜康有限责任公司 | 外科缝合系统 |
| JP6983893B2 (ja) | 2016-12-21 | 2021-12-17 | エシコン エルエルシーEthicon LLC | 外科用エンドエフェクタ及び交換式ツールアセンブリのためのロックアウト構成 |
| US20180168608A1 (en) | 2016-12-21 | 2018-06-21 | Ethicon Endo-Surgery, Llc | Surgical instrument system comprising an end effector lockout and a firing assembly lockout |
| US10973592B2 (en) | 2017-03-09 | 2021-04-13 | Memie Innovative Surgery Ltd. | Control console for surgical device with mechanical arms |
| US11779410B2 (en) | 2017-03-09 | 2023-10-10 | Momentis Surgical Ltd | Control console including an input arm for control of a surgical mechanical arm |
| CN107088093B (zh) * | 2017-04-28 | 2023-09-22 | 深圳前海前沿生命科学应用有限公司 | 一种多级柔性曲管医疗机器人的模块化驱动装置 |
| WO2018222562A1 (en) * | 2017-05-30 | 2018-12-06 | Bovie Medical Corporation | Electrosurgical apparatus with robotic tip |
| US11382638B2 (en) | 2017-06-20 | 2022-07-12 | Cilag Gmbh International | Closed loop feedback control of motor velocity of a surgical stapling and cutting instrument based on measured time over a specified displacement distance |
| US11517325B2 (en) | 2017-06-20 | 2022-12-06 | Cilag Gmbh International | Closed loop feedback control of motor velocity of a surgical stapling and cutting instrument based on measured displacement distance traveled over a specified time interval |
| US11653914B2 (en) | 2017-06-20 | 2023-05-23 | Cilag Gmbh International | Systems and methods for controlling motor velocity of a surgical stapling and cutting instrument according to articulation angle of end effector |
| US10327767B2 (en) | 2017-06-20 | 2019-06-25 | Ethicon Llc | Control of motor velocity of a surgical stapling and cutting instrument based on angle of articulation |
| USD879809S1 (en) | 2017-06-20 | 2020-03-31 | Ethicon Llc | Display panel with changeable graphical user interface |
| US10881399B2 (en) | 2017-06-20 | 2021-01-05 | Ethicon Llc | Techniques for adaptive control of motor velocity of a surgical stapling and cutting instrument |
| US10624633B2 (en) | 2017-06-20 | 2020-04-21 | Ethicon Llc | Systems and methods for controlling motor velocity of a surgical stapling and cutting instrument |
| US11090046B2 (en) | 2017-06-20 | 2021-08-17 | Cilag Gmbh International | Systems and methods for controlling displacement member motion of a surgical stapling and cutting instrument |
| USD879808S1 (en) | 2017-06-20 | 2020-03-31 | Ethicon Llc | Display panel with graphical user interface |
| US10888321B2 (en) | 2017-06-20 | 2021-01-12 | Ethicon Llc | Systems and methods for controlling velocity of a displacement member of a surgical stapling and cutting instrument |
| US10779820B2 (en) | 2017-06-20 | 2020-09-22 | Ethicon Llc | Systems and methods for controlling motor speed according to user input for a surgical instrument |
| US11071554B2 (en) | 2017-06-20 | 2021-07-27 | Cilag Gmbh International | Closed loop feedback control of motor velocity of a surgical stapling and cutting instrument based on magnitude of velocity error measurements |
| US12490980B2 (en) | 2017-06-20 | 2025-12-09 | Cilag Gmbh International | Surgical instrument having controllable articulation velocity |
| US10390841B2 (en) | 2017-06-20 | 2019-08-27 | Ethicon Llc | Control of motor velocity of a surgical stapling and cutting instrument based on angle of articulation |
| US10980537B2 (en) | 2017-06-20 | 2021-04-20 | Ethicon Llc | Closed loop feedback control of motor velocity of a surgical stapling and cutting instrument based on measured time over a specified number of shaft rotations |
| US10646220B2 (en) | 2017-06-20 | 2020-05-12 | Ethicon Llc | Systems and methods for controlling displacement member velocity for a surgical instrument |
| US10368864B2 (en) | 2017-06-20 | 2019-08-06 | Ethicon Llc | Systems and methods for controlling displaying motor velocity for a surgical instrument |
| US10813639B2 (en) | 2017-06-20 | 2020-10-27 | Ethicon Llc | Closed loop feedback control of motor velocity of a surgical stapling and cutting instrument based on system conditions |
| USD890784S1 (en) | 2017-06-20 | 2020-07-21 | Ethicon Llc | Display panel with changeable graphical user interface |
| US10307170B2 (en) | 2017-06-20 | 2019-06-04 | Ethicon Llc | Method for closed loop control of motor velocity of a surgical stapling and cutting instrument |
| US10881396B2 (en) | 2017-06-20 | 2021-01-05 | Ethicon Llc | Surgical instrument with variable duration trigger arrangement |
| US11090049B2 (en) | 2017-06-27 | 2021-08-17 | Cilag Gmbh International | Staple forming pocket arrangements |
| US10772629B2 (en) | 2017-06-27 | 2020-09-15 | Ethicon Llc | Surgical anvil arrangements |
| US10993716B2 (en) | 2017-06-27 | 2021-05-04 | Ethicon Llc | Surgical anvil arrangements |
| US10856869B2 (en) | 2017-06-27 | 2020-12-08 | Ethicon Llc | Surgical anvil arrangements |
| US11266405B2 (en) | 2017-06-27 | 2022-03-08 | Cilag Gmbh International | Surgical anvil manufacturing methods |
| US11324503B2 (en) | 2017-06-27 | 2022-05-10 | Cilag Gmbh International | Surgical firing member arrangements |
| US10211586B2 (en) | 2017-06-28 | 2019-02-19 | Ethicon Llc | Surgical shaft assemblies with watertight housings |
| EP3420947B1 (en) | 2017-06-28 | 2022-05-25 | Cilag GmbH International | Surgical instrument comprising selectively actuatable rotatable couplers |
| USD869655S1 (en) | 2017-06-28 | 2019-12-10 | Ethicon Llc | Surgical fastener cartridge |
| USD906355S1 (en) | 2017-06-28 | 2020-12-29 | Ethicon Llc | Display screen or portion thereof with a graphical user interface for a surgical instrument |
| US11484310B2 (en) | 2017-06-28 | 2022-11-01 | Cilag Gmbh International | Surgical instrument comprising a shaft including a closure tube profile |
| US10716614B2 (en) | 2017-06-28 | 2020-07-21 | Ethicon Llc | Surgical shaft assemblies with slip ring assemblies with increased contact pressure |
| US11246592B2 (en) | 2017-06-28 | 2022-02-15 | Cilag Gmbh International | Surgical instrument comprising an articulation system lockable to a frame |
| US11564686B2 (en) | 2017-06-28 | 2023-01-31 | Cilag Gmbh International | Surgical shaft assemblies with flexible interfaces |
| USD851762S1 (en) | 2017-06-28 | 2019-06-18 | Ethicon Llc | Anvil |
| BR112019027065B1 (pt) | 2017-06-28 | 2023-12-26 | Ethicon Llc | Instrumento cirúrgico e sistema cirúrgico |
| US10903685B2 (en) | 2017-06-28 | 2021-01-26 | Ethicon Llc | Surgical shaft assemblies with slip ring assemblies forming capacitive channels |
| US10765427B2 (en) | 2017-06-28 | 2020-09-08 | Ethicon Llc | Method for articulating a surgical instrument |
| US11259805B2 (en) | 2017-06-28 | 2022-03-01 | Cilag Gmbh International | Surgical instrument comprising firing member supports |
| US20190000459A1 (en) | 2017-06-28 | 2019-01-03 | Ethicon Llc | Surgical instruments with jaws constrained to pivot about an axis upon contact with a closure member that is parked in close proximity to the pivot axis |
| USD854151S1 (en) | 2017-06-28 | 2019-07-16 | Ethicon Llc | Surgical instrument shaft |
| US10398434B2 (en) | 2017-06-29 | 2019-09-03 | Ethicon Llc | Closed loop velocity control of closure member for robotic surgical instrument |
| US11007022B2 (en) | 2017-06-29 | 2021-05-18 | Ethicon Llc | Closed loop velocity control techniques based on sensed tissue parameters for robotic surgical instrument |
| US10258418B2 (en) | 2017-06-29 | 2019-04-16 | Ethicon Llc | System for controlling articulation forces |
| US10932772B2 (en) | 2017-06-29 | 2021-03-02 | Ethicon Llc | Methods for closed loop velocity control for robotic surgical instrument |
| US10898183B2 (en) | 2017-06-29 | 2021-01-26 | Ethicon Llc | Robotic surgical instrument with closed loop feedback techniques for advancement of closure member during firing |
| US11944300B2 (en) | 2017-08-03 | 2024-04-02 | Cilag Gmbh International | Method for operating a surgical system bailout |
| US11304695B2 (en) | 2017-08-03 | 2022-04-19 | Cilag Gmbh International | Surgical system shaft interconnection |
| US11974742B2 (en) | 2017-08-03 | 2024-05-07 | Cilag Gmbh International | Surgical system comprising an articulation bailout |
| US11471155B2 (en) | 2017-08-03 | 2022-10-18 | Cilag Gmbh International | Surgical system bailout |
| US11399829B2 (en) | 2017-09-29 | 2022-08-02 | Cilag Gmbh International | Systems and methods of initiating a power shutdown mode for a surgical instrument |
| USD907648S1 (en) | 2017-09-29 | 2021-01-12 | Ethicon Llc | Display screen or portion thereof with animated graphical user interface |
| US10796471B2 (en) | 2017-09-29 | 2020-10-06 | Ethicon Llc | Systems and methods of displaying a knife position for a surgical instrument |
| USD907647S1 (en) | 2017-09-29 | 2021-01-12 | Ethicon Llc | Display screen or portion thereof with animated graphical user interface |
| US10765429B2 (en) | 2017-09-29 | 2020-09-08 | Ethicon Llc | Systems and methods for providing alerts according to the operational state of a surgical instrument |
| US10729501B2 (en) | 2017-09-29 | 2020-08-04 | Ethicon Llc | Systems and methods for language selection of a surgical instrument |
| US10743872B2 (en) | 2017-09-29 | 2020-08-18 | Ethicon Llc | System and methods for controlling a display of a surgical instrument |
| USD917500S1 (en) | 2017-09-29 | 2021-04-27 | Ethicon Llc | Display screen or portion thereof with graphical user interface |
| US11134944B2 (en) | 2017-10-30 | 2021-10-05 | Cilag Gmbh International | Surgical stapler knife motion controls |
| US11090075B2 (en) | 2017-10-30 | 2021-08-17 | Cilag Gmbh International | Articulation features for surgical end effector |
| US10842490B2 (en) | 2017-10-31 | 2020-11-24 | Ethicon Llc | Cartridge body design with force reduction based on firing completion |
| US10779903B2 (en) | 2017-10-31 | 2020-09-22 | Ethicon Llc | Positive shaft rotation lock activated by jaw closure |
| NL2019909B1 (en) | 2017-11-14 | 2019-05-20 | Academisch Ziekenhuis Leiden | SYSTEM, METHOD AND CATHETER FOR PITUITARY AND BRAIN IMPLANTATION |
| US11071543B2 (en) | 2017-12-15 | 2021-07-27 | Cilag Gmbh International | Surgical end effectors with clamping assemblies configured to increase jaw aperture ranges |
| US10743875B2 (en) | 2017-12-15 | 2020-08-18 | Ethicon Llc | Surgical end effectors with jaw stiffener arrangements configured to permit monitoring of firing member |
| US10828033B2 (en) | 2017-12-15 | 2020-11-10 | Ethicon Llc | Handheld electromechanical surgical instruments with improved motor control arrangements for positioning components of an adapter coupled thereto |
| US10779826B2 (en) | 2017-12-15 | 2020-09-22 | Ethicon Llc | Methods of operating surgical end effectors |
| US10869666B2 (en) | 2017-12-15 | 2020-12-22 | Ethicon Llc | Adapters with control systems for controlling multiple motors of an electromechanical surgical instrument |
| US10779825B2 (en) | 2017-12-15 | 2020-09-22 | Ethicon Llc | Adapters with end effector position sensing and control arrangements for use in connection with electromechanical surgical instruments |
| US10966718B2 (en) | 2017-12-15 | 2021-04-06 | Ethicon Llc | Dynamic clamping assemblies with improved wear characteristics for use in connection with electromechanical surgical instruments |
| US10743874B2 (en) | 2017-12-15 | 2020-08-18 | Ethicon Llc | Sealed adapters for use with electromechanical surgical instruments |
| US10687813B2 (en) | 2017-12-15 | 2020-06-23 | Ethicon Llc | Adapters with firing stroke sensing arrangements for use in connection with electromechanical surgical instruments |
| US11197670B2 (en) | 2017-12-15 | 2021-12-14 | Cilag Gmbh International | Surgical end effectors with pivotal jaws configured to touch at their respective distal ends when fully closed |
| US11006955B2 (en) | 2017-12-15 | 2021-05-18 | Ethicon Llc | End effectors with positive jaw opening features for use with adapters for electromechanical surgical instruments |
| US11033267B2 (en) | 2017-12-15 | 2021-06-15 | Ethicon Llc | Systems and methods of controlling a clamping member firing rate of a surgical instrument |
| US11020112B2 (en) | 2017-12-19 | 2021-06-01 | Ethicon Llc | Surgical tools configured for interchangeable use with different controller interfaces |
| US10835330B2 (en) | 2017-12-19 | 2020-11-17 | Ethicon Llc | Method for determining the position of a rotatable jaw of a surgical instrument attachment assembly |
| US10716565B2 (en) | 2017-12-19 | 2020-07-21 | Ethicon Llc | Surgical instruments with dual articulation drivers |
| USD910847S1 (en) | 2017-12-19 | 2021-02-16 | Ethicon Llc | Surgical instrument assembly |
| US11045270B2 (en) | 2017-12-19 | 2021-06-29 | Cilag Gmbh International | Robotic attachment comprising exterior drive actuator |
| US10729509B2 (en) | 2017-12-19 | 2020-08-04 | Ethicon Llc | Surgical instrument comprising closure and firing locking mechanism |
| US11076853B2 (en) | 2017-12-21 | 2021-08-03 | Cilag Gmbh International | Systems and methods of displaying a knife position during transection for a surgical instrument |
| US11311290B2 (en) | 2017-12-21 | 2022-04-26 | Cilag Gmbh International | Surgical instrument comprising an end effector dampener |
| US12336705B2 (en) | 2017-12-21 | 2025-06-24 | Cilag Gmbh International | Continuous use self-propelled stapling instrument |
| US11129680B2 (en) | 2017-12-21 | 2021-09-28 | Cilag Gmbh International | Surgical instrument comprising a projector |
| US11364027B2 (en) | 2017-12-21 | 2022-06-21 | Cilag Gmbh International | Surgical instrument comprising speed control |
| JP7183062B2 (ja) * | 2018-03-23 | 2022-12-05 | キヤノン株式会社 | 連続体ロボット制御装置、連続体ロボット制御方法及びプログラム |
| KR102069601B1 (ko) | 2018-06-11 | 2020-01-23 | 한국과학기술연구원 | 가변 강성 메커니즘이 적용된 튜브 구조체 |
| USD914878S1 (en) | 2018-08-20 | 2021-03-30 | Ethicon Llc | Surgical instrument anvil |
| US10856870B2 (en) | 2018-08-20 | 2020-12-08 | Ethicon Llc | Switching arrangements for motor powered articulatable surgical instruments |
| US11253256B2 (en) | 2018-08-20 | 2022-02-22 | Cilag Gmbh International | Articulatable motor powered surgical instruments with dedicated articulation motor arrangements |
| US10912559B2 (en) | 2018-08-20 | 2021-02-09 | Ethicon Llc | Reinforced deformable anvil tip for surgical stapler anvil |
| US11207065B2 (en) | 2018-08-20 | 2021-12-28 | Cilag Gmbh International | Method for fabricating surgical stapler anvils |
| US20200054321A1 (en) | 2018-08-20 | 2020-02-20 | Ethicon Llc | Surgical instruments with progressive jaw closure arrangements |
| US10779821B2 (en) | 2018-08-20 | 2020-09-22 | Ethicon Llc | Surgical stapler anvils with tissue stop features configured to avoid tissue pinch |
| US11083458B2 (en) | 2018-08-20 | 2021-08-10 | Cilag Gmbh International | Powered surgical instruments with clutching arrangements to convert linear drive motions to rotary drive motions |
| US11324501B2 (en) | 2018-08-20 | 2022-05-10 | Cilag Gmbh International | Surgical stapling devices with improved closure members |
| US11039834B2 (en) | 2018-08-20 | 2021-06-22 | Cilag Gmbh International | Surgical stapler anvils with staple directing protrusions and tissue stability features |
| US11291440B2 (en) | 2018-08-20 | 2022-04-05 | Cilag Gmbh International | Method for operating a powered articulatable surgical instrument |
| US10842492B2 (en) | 2018-08-20 | 2020-11-24 | Ethicon Llc | Powered articulatable surgical instruments with clutching and locking arrangements for linking an articulation drive system to a firing drive system |
| US11045192B2 (en) | 2018-08-20 | 2021-06-29 | Cilag Gmbh International | Fabricating techniques for surgical stapler anvils |
| US11446055B1 (en) | 2018-10-18 | 2022-09-20 | Lumoptik, Inc. | Light assisted needle placement system and method |
| CN111135429A (zh) * | 2018-11-02 | 2020-05-12 | 里特材料科技股份有限公司 | 具有形状记忆特性及超弹性的合金线材及其制造方法与应用 |
| US11147553B2 (en) | 2019-03-25 | 2021-10-19 | Cilag Gmbh International | Firing drive arrangements for surgical systems |
| US11147551B2 (en) | 2019-03-25 | 2021-10-19 | Cilag Gmbh International | Firing drive arrangements for surgical systems |
| US11696761B2 (en) | 2019-03-25 | 2023-07-11 | Cilag Gmbh International | Firing drive arrangements for surgical systems |
| US11172929B2 (en) | 2019-03-25 | 2021-11-16 | Cilag Gmbh International | Articulation drive arrangements for surgical systems |
| WO2020210598A1 (en) * | 2019-04-10 | 2020-10-15 | Saint Louis University | Systems and methods for guiding surgical tools |
| US11426251B2 (en) | 2019-04-30 | 2022-08-30 | Cilag Gmbh International | Articulation directional lights on a surgical instrument |
| US11253254B2 (en) | 2019-04-30 | 2022-02-22 | Cilag Gmbh International | Shaft rotation actuator on a surgical instrument |
| US11648009B2 (en) | 2019-04-30 | 2023-05-16 | Cilag Gmbh International | Rotatable jaw tip for a surgical instrument |
| US11452528B2 (en) | 2019-04-30 | 2022-09-27 | Cilag Gmbh International | Articulation actuators for a surgical instrument |
| US11432816B2 (en) | 2019-04-30 | 2022-09-06 | Cilag Gmbh International | Articulation pin for a surgical instrument |
| US11471157B2 (en) | 2019-04-30 | 2022-10-18 | Cilag Gmbh International | Articulation control mapping for a surgical instrument |
| US11903581B2 (en) | 2019-04-30 | 2024-02-20 | Cilag Gmbh International | Methods for stapling tissue using a surgical instrument |
| US11628020B2 (en) | 2019-06-19 | 2023-04-18 | Virtuoso Surgical, Inc. | Insertable robot for minimally invasive surgery |
| US11246678B2 (en) | 2019-06-28 | 2022-02-15 | Cilag Gmbh International | Surgical stapling system having a frangible RFID tag |
| US11224497B2 (en) | 2019-06-28 | 2022-01-18 | Cilag Gmbh International | Surgical systems with multiple RFID tags |
| US11219455B2 (en) | 2019-06-28 | 2022-01-11 | Cilag Gmbh International | Surgical instrument including a lockout key |
| US11497492B2 (en) | 2019-06-28 | 2022-11-15 | Cilag Gmbh International | Surgical instrument including an articulation lock |
| US11478241B2 (en) | 2019-06-28 | 2022-10-25 | Cilag Gmbh International | Staple cartridge including projections |
| US11259803B2 (en) | 2019-06-28 | 2022-03-01 | Cilag Gmbh International | Surgical stapling system having an information encryption protocol |
| US11426167B2 (en) | 2019-06-28 | 2022-08-30 | Cilag Gmbh International | Mechanisms for proper anvil attachment surgical stapling head assembly |
| US12004740B2 (en) | 2019-06-28 | 2024-06-11 | Cilag Gmbh International | Surgical stapling system having an information decryption protocol |
| US11051807B2 (en) | 2019-06-28 | 2021-07-06 | Cilag Gmbh International | Packaging assembly including a particulate trap |
| US11298127B2 (en) | 2019-06-28 | 2022-04-12 | Cilag GmbH Interational | Surgical stapling system having a lockout mechanism for an incompatible cartridge |
| US11350938B2 (en) | 2019-06-28 | 2022-06-07 | Cilag Gmbh International | Surgical instrument comprising an aligned rfid sensor |
| US11660163B2 (en) | 2019-06-28 | 2023-05-30 | Cilag Gmbh International | Surgical system with RFID tags for updating motor assembly parameters |
| US11464601B2 (en) | 2019-06-28 | 2022-10-11 | Cilag Gmbh International | Surgical instrument comprising an RFID system for tracking a movable component |
| US11291451B2 (en) | 2019-06-28 | 2022-04-05 | Cilag Gmbh International | Surgical instrument with battery compatibility verification functionality |
| US11553971B2 (en) | 2019-06-28 | 2023-01-17 | Cilag Gmbh International | Surgical RFID assemblies for display and communication |
| US11627959B2 (en) | 2019-06-28 | 2023-04-18 | Cilag Gmbh International | Surgical instruments including manual and powered system lockouts |
| US11638587B2 (en) | 2019-06-28 | 2023-05-02 | Cilag Gmbh International | RFID identification systems for surgical instruments |
| US11376098B2 (en) | 2019-06-28 | 2022-07-05 | Cilag Gmbh International | Surgical instrument system comprising an RFID system |
| US11684434B2 (en) | 2019-06-28 | 2023-06-27 | Cilag Gmbh International | Surgical RFID assemblies for instrument operational setting control |
| US11523822B2 (en) | 2019-06-28 | 2022-12-13 | Cilag Gmbh International | Battery pack including a circuit interrupter |
| US11298132B2 (en) | 2019-06-28 | 2022-04-12 | Cilag GmbH Inlernational | Staple cartridge including a honeycomb extension |
| US11399837B2 (en) | 2019-06-28 | 2022-08-02 | Cilag Gmbh International | Mechanisms for motor control adjustments of a motorized surgical instrument |
| US11771419B2 (en) | 2019-06-28 | 2023-10-03 | Cilag Gmbh International | Packaging for a replaceable component of a surgical stapling system |
| US11480068B2 (en) | 2019-10-15 | 2022-10-25 | General Electric Company | Systems and method of servicing a turbomachine |
| EP4044954A1 (en) | 2019-10-17 | 2022-08-24 | Intuitive Surgical Operations, Inc. | Surgical tool with nested shaft tubes |
| CN114828932B (zh) * | 2019-10-23 | 2025-08-26 | 佳能美国公司 | 具有分段可弯曲区段的医学设备 |
| KR102321836B1 (ko) | 2019-12-09 | 2021-11-08 | 한국과학기술연구원 | 가변 강성 구조를 갖는 니들 제어 시스템 및 방법 |
| US11701111B2 (en) | 2019-12-19 | 2023-07-18 | Cilag Gmbh International | Method for operating a surgical stapling instrument |
| US11559304B2 (en) | 2019-12-19 | 2023-01-24 | Cilag Gmbh International | Surgical instrument comprising a rapid closure mechanism |
| US11529137B2 (en) | 2019-12-19 | 2022-12-20 | Cilag Gmbh International | Staple cartridge comprising driver retention members |
| US11234698B2 (en) | 2019-12-19 | 2022-02-01 | Cilag Gmbh International | Stapling system comprising a clamp lockout and a firing lockout |
| US11446029B2 (en) | 2019-12-19 | 2022-09-20 | Cilag Gmbh International | Staple cartridge comprising projections extending from a curved deck surface |
| US11911032B2 (en) | 2019-12-19 | 2024-02-27 | Cilag Gmbh International | Staple cartridge comprising a seating cam |
| US11291447B2 (en) | 2019-12-19 | 2022-04-05 | Cilag Gmbh International | Stapling instrument comprising independent jaw closing and staple firing systems |
| US11931033B2 (en) | 2019-12-19 | 2024-03-19 | Cilag Gmbh International | Staple cartridge comprising a latch lockout |
| US11464512B2 (en) | 2019-12-19 | 2022-10-11 | Cilag Gmbh International | Staple cartridge comprising a curved deck surface |
| US11504122B2 (en) | 2019-12-19 | 2022-11-22 | Cilag Gmbh International | Surgical instrument comprising a nested firing member |
| US11844520B2 (en) | 2019-12-19 | 2023-12-19 | Cilag Gmbh International | Staple cartridge comprising driver retention members |
| US11304696B2 (en) | 2019-12-19 | 2022-04-19 | Cilag Gmbh International | Surgical instrument comprising a powered articulation system |
| US11576672B2 (en) | 2019-12-19 | 2023-02-14 | Cilag Gmbh International | Surgical instrument comprising a closure system including a closure member and an opening member driven by a drive screw |
| US11607219B2 (en) | 2019-12-19 | 2023-03-21 | Cilag Gmbh International | Staple cartridge comprising a detachable tissue cutting knife |
| US12035913B2 (en) | 2019-12-19 | 2024-07-16 | Cilag Gmbh International | Staple cartridge comprising a deployable knife |
| US11529139B2 (en) | 2019-12-19 | 2022-12-20 | Cilag Gmbh International | Motor driven surgical instrument |
| CN111166994A (zh) * | 2020-02-05 | 2020-05-19 | 上海汇禾医疗科技有限公司 | 套管组件及包含该套管组件的器械运输系统 |
| JP7784730B2 (ja) | 2020-02-26 | 2025-12-12 | アピックス メディカル コーポレーション | 可撓性のシャフトを備えた電気外科装置 |
| CN113520611B (zh) * | 2020-04-13 | 2023-08-25 | 上海微创医疗机器人(集团)股份有限公司 | 无菌隔离机构、持镜臂及持镜机器人 |
| US12419704B2 (en) | 2020-05-20 | 2025-09-23 | Khalifa University of Science and Technology | Concentric tube robots with improved stability for minimally invasive surgery |
| USD975851S1 (en) | 2020-06-02 | 2023-01-17 | Cilag Gmbh International | Staple cartridge |
| USD967421S1 (en) | 2020-06-02 | 2022-10-18 | Cilag Gmbh International | Staple cartridge |
| USD974560S1 (en) | 2020-06-02 | 2023-01-03 | Cilag Gmbh International | Staple cartridge |
| USD966512S1 (en) | 2020-06-02 | 2022-10-11 | Cilag Gmbh International | Staple cartridge |
| USD975850S1 (en) | 2020-06-02 | 2023-01-17 | Cilag Gmbh International | Staple cartridge |
| USD975278S1 (en) | 2020-06-02 | 2023-01-10 | Cilag Gmbh International | Staple cartridge |
| USD976401S1 (en) | 2020-06-02 | 2023-01-24 | Cilag Gmbh International | Staple cartridge |
| US12220126B2 (en) | 2020-07-28 | 2025-02-11 | Cilag Gmbh International | Surgical instruments with double pivot articulation joint arrangements |
| US12329410B2 (en) * | 2020-08-12 | 2025-06-17 | Mazor Robotics Ltd. | Cannulation devices, systems, and methods |
| USD1013170S1 (en) | 2020-10-29 | 2024-01-30 | Cilag Gmbh International | Surgical instrument assembly |
| US11779330B2 (en) | 2020-10-29 | 2023-10-10 | Cilag Gmbh International | Surgical instrument comprising a jaw alignment system |
| US11534259B2 (en) | 2020-10-29 | 2022-12-27 | Cilag Gmbh International | Surgical instrument comprising an articulation indicator |
| US11896217B2 (en) | 2020-10-29 | 2024-02-13 | Cilag Gmbh International | Surgical instrument comprising an articulation lock |
| US11617577B2 (en) | 2020-10-29 | 2023-04-04 | Cilag Gmbh International | Surgical instrument comprising a sensor configured to sense whether an articulation drive of the surgical instrument is actuatable |
| US11844518B2 (en) | 2020-10-29 | 2023-12-19 | Cilag Gmbh International | Method for operating a surgical instrument |
| US11717289B2 (en) | 2020-10-29 | 2023-08-08 | Cilag Gmbh International | Surgical instrument comprising an indicator which indicates that an articulation drive is actuatable |
| USD980425S1 (en) | 2020-10-29 | 2023-03-07 | Cilag Gmbh International | Surgical instrument assembly |
| US11452526B2 (en) | 2020-10-29 | 2022-09-27 | Cilag Gmbh International | Surgical instrument comprising a staged voltage regulation start-up system |
| US11931025B2 (en) | 2020-10-29 | 2024-03-19 | Cilag Gmbh International | Surgical instrument comprising a releasable closure drive lock |
| US12053175B2 (en) | 2020-10-29 | 2024-08-06 | Cilag Gmbh International | Surgical instrument comprising a stowed closure actuator stop |
| US11517390B2 (en) | 2020-10-29 | 2022-12-06 | Cilag Gmbh International | Surgical instrument comprising a limited travel switch |
| US11627960B2 (en) | 2020-12-02 | 2023-04-18 | Cilag Gmbh International | Powered surgical instruments with smart reload with separately attachable exteriorly mounted wiring connections |
| US11737751B2 (en) | 2020-12-02 | 2023-08-29 | Cilag Gmbh International | Devices and methods of managing energy dissipated within sterile barriers of surgical instrument housings |
| US11678882B2 (en) | 2020-12-02 | 2023-06-20 | Cilag Gmbh International | Surgical instruments with interactive features to remedy incidental sled movements |
| US12471982B2 (en) | 2020-12-02 | 2025-11-18 | Cilag Gmbh International | Method for tissue treatment by surgical instrument |
| US11653915B2 (en) | 2020-12-02 | 2023-05-23 | Cilag Gmbh International | Surgical instruments with sled location detection and adjustment features |
| US11744581B2 (en) | 2020-12-02 | 2023-09-05 | Cilag Gmbh International | Powered surgical instruments with multi-phase tissue treatment |
| US11944296B2 (en) | 2020-12-02 | 2024-04-02 | Cilag Gmbh International | Powered surgical instruments with external connectors |
| US11653920B2 (en) | 2020-12-02 | 2023-05-23 | Cilag Gmbh International | Powered surgical instruments with communication interfaces through sterile barrier |
| US11890010B2 (en) | 2020-12-02 | 2024-02-06 | Cllag GmbH International | Dual-sided reinforced reload for surgical instruments |
| US11849943B2 (en) | 2020-12-02 | 2023-12-26 | Cilag Gmbh International | Surgical instrument with cartridge release mechanisms |
| US11806107B2 (en) * | 2020-12-07 | 2023-11-07 | Virtuoso Surgical, Inc. | Physician input device for a concentric tube surgical robot |
| US20220241029A1 (en) * | 2021-02-02 | 2022-08-04 | Virtuoso Surgical, Inc. | Concentric tube apparatus for minimally invasive surgery |
| US11793514B2 (en) | 2021-02-26 | 2023-10-24 | Cilag Gmbh International | Staple cartridge comprising sensor array which may be embedded in cartridge body |
| US11696757B2 (en) | 2021-02-26 | 2023-07-11 | Cilag Gmbh International | Monitoring of internal systems to detect and track cartridge motion status |
| US11751869B2 (en) | 2021-02-26 | 2023-09-12 | Cilag Gmbh International | Monitoring of multiple sensors over time to detect moving characteristics of tissue |
| US12324580B2 (en) | 2021-02-26 | 2025-06-10 | Cilag Gmbh International | Method of powering and communicating with a staple cartridge |
| US11749877B2 (en) | 2021-02-26 | 2023-09-05 | Cilag Gmbh International | Stapling instrument comprising a signal antenna |
| US11812964B2 (en) | 2021-02-26 | 2023-11-14 | Cilag Gmbh International | Staple cartridge comprising a power management circuit |
| US11980362B2 (en) | 2021-02-26 | 2024-05-14 | Cilag Gmbh International | Surgical instrument system comprising a power transfer coil |
| US11950777B2 (en) | 2021-02-26 | 2024-04-09 | Cilag Gmbh International | Staple cartridge comprising an information access control system |
| US11744583B2 (en) | 2021-02-26 | 2023-09-05 | Cilag Gmbh International | Distal communication array to tune frequency of RF systems |
| US11950779B2 (en) | 2021-02-26 | 2024-04-09 | Cilag Gmbh International | Method of powering and communicating with a staple cartridge |
| US11925349B2 (en) | 2021-02-26 | 2024-03-12 | Cilag Gmbh International | Adjustment to transfer parameters to improve available power |
| US12108951B2 (en) | 2021-02-26 | 2024-10-08 | Cilag Gmbh International | Staple cartridge comprising a sensing array and a temperature control system |
| US11730473B2 (en) | 2021-02-26 | 2023-08-22 | Cilag Gmbh International | Monitoring of manufacturing life-cycle |
| US11723657B2 (en) | 2021-02-26 | 2023-08-15 | Cilag Gmbh International | Adjustable communication based on available bandwidth and power capacity |
| US11701113B2 (en) | 2021-02-26 | 2023-07-18 | Cilag Gmbh International | Stapling instrument comprising a separate power antenna and a data transfer antenna |
| US20220287680A1 (en) * | 2021-03-09 | 2022-09-15 | GE Precision Healthcare LLC | Shape Memory Support For Interventional Device Insertion Tubes |
| US11759202B2 (en) | 2021-03-22 | 2023-09-19 | Cilag Gmbh International | Staple cartridge comprising an implantable layer |
| US11737749B2 (en) | 2021-03-22 | 2023-08-29 | Cilag Gmbh International | Surgical stapling instrument comprising a retraction system |
| US11806011B2 (en) | 2021-03-22 | 2023-11-07 | Cilag Gmbh International | Stapling instrument comprising tissue compression systems |
| US11826042B2 (en) | 2021-03-22 | 2023-11-28 | Cilag Gmbh International | Surgical instrument comprising a firing drive including a selectable leverage mechanism |
| US11717291B2 (en) | 2021-03-22 | 2023-08-08 | Cilag Gmbh International | Staple cartridge comprising staples configured to apply different tissue compression |
| US11826012B2 (en) | 2021-03-22 | 2023-11-28 | Cilag Gmbh International | Stapling instrument comprising a pulsed motor-driven firing rack |
| US11723658B2 (en) | 2021-03-22 | 2023-08-15 | Cilag Gmbh International | Staple cartridge comprising a firing lockout |
| US11786243B2 (en) | 2021-03-24 | 2023-10-17 | Cilag Gmbh International | Firing members having flexible portions for adapting to a load during a surgical firing stroke |
| US11944336B2 (en) | 2021-03-24 | 2024-04-02 | Cilag Gmbh International | Joint arrangements for multi-planar alignment and support of operational drive shafts in articulatable surgical instruments |
| US11896218B2 (en) | 2021-03-24 | 2024-02-13 | Cilag Gmbh International | Method of using a powered stapling device |
| US11857183B2 (en) | 2021-03-24 | 2024-01-02 | Cilag Gmbh International | Stapling assembly components having metal substrates and plastic bodies |
| US11793516B2 (en) | 2021-03-24 | 2023-10-24 | Cilag Gmbh International | Surgical staple cartridge comprising longitudinal support beam |
| US11832816B2 (en) | 2021-03-24 | 2023-12-05 | Cilag Gmbh International | Surgical stapling assembly comprising nonplanar staples and planar staples |
| US12102323B2 (en) | 2021-03-24 | 2024-10-01 | Cilag Gmbh International | Rotary-driven surgical stapling assembly comprising a floatable component |
| US11903582B2 (en) | 2021-03-24 | 2024-02-20 | Cilag Gmbh International | Leveraging surfaces for cartridge installation |
| US11849944B2 (en) | 2021-03-24 | 2023-12-26 | Cilag Gmbh International | Drivers for fastener cartridge assemblies having rotary drive screws |
| US11896219B2 (en) | 2021-03-24 | 2024-02-13 | Cilag Gmbh International | Mating features between drivers and underside of a cartridge deck |
| US11786239B2 (en) | 2021-03-24 | 2023-10-17 | Cilag Gmbh International | Surgical instrument articulation joint arrangements comprising multiple moving linkage features |
| US11744603B2 (en) | 2021-03-24 | 2023-09-05 | Cilag Gmbh International | Multi-axis pivot joints for surgical instruments and methods for manufacturing same |
| US11849945B2 (en) | 2021-03-24 | 2023-12-26 | Cilag Gmbh International | Rotary-driven surgical stapling assembly comprising eccentrically driven firing member |
| US20220378425A1 (en) | 2021-05-28 | 2022-12-01 | Cilag Gmbh International | Stapling instrument comprising a control system that controls a firing stroke length |
| US12433608B2 (en) * | 2021-08-19 | 2025-10-07 | Board Of Regents, The University Of Texas System | Fully steerable flexible curved-drilling robot device, system and method |
| US11877745B2 (en) | 2021-10-18 | 2024-01-23 | Cilag Gmbh International | Surgical stapling assembly having longitudinally-repeating staple leg clusters |
| US11980363B2 (en) | 2021-10-18 | 2024-05-14 | Cilag Gmbh International | Row-to-row staple array variations |
| US11957337B2 (en) | 2021-10-18 | 2024-04-16 | Cilag Gmbh International | Surgical stapling assembly with offset ramped drive surfaces |
| US12239317B2 (en) | 2021-10-18 | 2025-03-04 | Cilag Gmbh International | Anvil comprising an arrangement of forming pockets proximal to tissue stop |
| US12089841B2 (en) | 2021-10-28 | 2024-09-17 | Cilag CmbH International | Staple cartridge identification systems |
| US12432790B2 (en) | 2021-10-28 | 2025-09-30 | Cilag Gmbh International | Method and device for transmitting UART communications over a security short range wireless communication |
| US11937816B2 (en) | 2021-10-28 | 2024-03-26 | Cilag Gmbh International | Electrical lead arrangements for surgical instruments |
| US20250025022A1 (en) * | 2021-12-01 | 2025-01-23 | Tamar Robotics Ltd | Dual robotic endoscope configuration for tissue removal |
| CN120094060B (zh) * | 2025-05-06 | 2025-09-02 | 山西省汾阳医院 | 一种多功能呼吸介入气管插管 |
Citations (6)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JPH10295822A (ja) * | 1997-04-04 | 1998-11-10 | Eclipse Surgical Technol Inc | 操縦可能なカテーテル |
| JP2000042116A (ja) * | 1998-07-10 | 2000-02-15 | Mitsubishi Electric Inf Technol Center America Inc | 医療器具操作装置 |
| US20020087048A1 (en) * | 1998-02-24 | 2002-07-04 | Brock David L. | Flexible instrument |
| JP2002191571A (ja) * | 2000-12-26 | 2002-07-09 | Hisayuki Mukai | 電極カテーテル |
| US20030109852A1 (en) * | 2001-12-11 | 2003-06-12 | Cardiac Pacemakers, Inc. | Deflectable telescoping guide catheter |
| US20030144657A1 (en) * | 2002-01-28 | 2003-07-31 | Cardiac Pacemakers, Inc. | Inner and outer telescoping catheter delivery system |
Family Cites Families (10)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| US4935017A (en) * | 1988-04-29 | 1990-06-19 | C. R. Bard, Inc. | Variable shaped catheter system and method for catheterization |
| US6623449B2 (en) * | 1991-07-15 | 2003-09-23 | Larry D. Paskar | Catheter with up-going and down-going configurations |
| US5971767A (en) | 1996-09-16 | 1999-10-26 | The Research Foundation Of State University Of New York | System and method for performing a three-dimensional virtual examination |
| EP1459692A1 (en) | 1996-10-23 | 2004-09-22 | Oratec Interventions, Inc. | Method and apparatus for treating intervertebral discs |
| US7090683B2 (en) * | 1998-02-24 | 2006-08-15 | Hansen Medical, Inc. | Flexible instrument |
| US6800056B2 (en) * | 2000-04-03 | 2004-10-05 | Neoguide Systems, Inc. | Endoscope with guiding apparatus |
| EP1284665A2 (en) * | 2000-05-30 | 2003-02-26 | Genicon LC | Trocar system |
| US7115134B2 (en) * | 2002-07-22 | 2006-10-03 | Chambers Technology, Llc. | Catheter with flexible tip and shape retention |
| US7766904B2 (en) * | 2003-01-31 | 2010-08-03 | Iridex Corporation | Adjustable laser probe for use in vitreoretinal surgery |
| JP2009514610A (ja) * | 2005-11-08 | 2009-04-09 | トラスティーズ オブ ボストン ユニバーシティ | 複数の変形可能な細長い部材を用いたマニピュレータ |
-
2006
- 2006-11-15 US US12/084,979 patent/US8152756B2/en active Active
- 2006-11-15 WO PCT/US2006/044386 patent/WO2007059233A2/en not_active Ceased
- 2006-11-15 CN CN2006800500468A patent/CN101351236B/zh active Active
- 2006-11-15 EP EP06844376.1A patent/EP1973595B1/en active Active
- 2006-11-15 JP JP2008541319A patent/JP5276987B2/ja active Active
- 2006-11-15 CA CA2630061A patent/CA2630061C/en active Active
-
2012
- 2012-03-09 US US13/416,772 patent/US8715226B2/en active Active
- 2012-06-20 JP JP2012139088A patent/JP5550682B2/ja active Active
-
2014
- 2014-01-06 JP JP2014000372A patent/JP5964335B2/ja active Active
-
2015
- 2015-05-07 JP JP2015094824A patent/JP6290822B2/ja active Active
Patent Citations (6)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JPH10295822A (ja) * | 1997-04-04 | 1998-11-10 | Eclipse Surgical Technol Inc | 操縦可能なカテーテル |
| US20020087048A1 (en) * | 1998-02-24 | 2002-07-04 | Brock David L. | Flexible instrument |
| JP2000042116A (ja) * | 1998-07-10 | 2000-02-15 | Mitsubishi Electric Inf Technol Center America Inc | 医療器具操作装置 |
| JP2002191571A (ja) * | 2000-12-26 | 2002-07-09 | Hisayuki Mukai | 電極カテーテル |
| US20030109852A1 (en) * | 2001-12-11 | 2003-06-12 | Cardiac Pacemakers, Inc. | Deflectable telescoping guide catheter |
| US20030144657A1 (en) * | 2002-01-28 | 2003-07-31 | Cardiac Pacemakers, Inc. | Inner and outer telescoping catheter delivery system |
Also Published As
| Publication number | Publication date |
|---|---|
| CN101351236A (zh) | 2009-01-21 |
| JP5550682B2 (ja) | 2014-07-16 |
| US20130018303A1 (en) | 2013-01-17 |
| JP5276987B2 (ja) | 2013-08-28 |
| CA2630061A1 (en) | 2007-05-24 |
| EP1973595B1 (en) | 2018-10-31 |
| JP2015198940A (ja) | 2015-11-12 |
| US8715226B2 (en) | 2014-05-06 |
| US20090171271A1 (en) | 2009-07-02 |
| WO2007059233A3 (en) | 2008-01-31 |
| CA2630061C (en) | 2015-03-17 |
| CN101351236B (zh) | 2013-05-29 |
| JP2009515657A (ja) | 2009-04-16 |
| JP6290822B2 (ja) | 2018-03-07 |
| WO2007059233A2 (en) | 2007-05-24 |
| US8152756B2 (en) | 2012-04-10 |
| JP5964335B2 (ja) | 2016-08-03 |
| JP2012228523A (ja) | 2012-11-22 |
| EP1973595A4 (en) | 2011-07-06 |
| EP1973595A2 (en) | 2008-10-01 |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| JP6290822B2 (ja) | バイオセンシング及び外科的処置のための能動的カニューレ | |
| US20220152356A1 (en) | Flexible instrument with nested conduits | |
| Taylor et al. | Medical robotics and computer-integrated surgery | |
| JP7267309B2 (ja) | 高力器具を有するロボット医療システム | |
| CN107184272B (zh) | 复合曲线式导航导管 | |
| CN105658270B (zh) | 带有嵌入式致动导管的柔性器械 | |
| JP2021519141A (ja) | 可変曲げ剛性プロファイルを有する医療用器具 | |
| Wang et al. | Design of a multi-arm concentric-tube robot system for transnasal surgery | |
| JP2020516342A (ja) | 超弾性医療機器 | |
| US20070250074A1 (en) | Flexible instrument | |
| JP2009507617A (ja) | 経腔的及び他の操作を行うための方法及び装置 | |
| CN115334993A (zh) | 用于医疗器械的约束运动控制的系统和方法 | |
| Song et al. | A novel continuum overtube with improved triangulation for flexible robotic endoscopy | |
| Culmone et al. | Follow-the-leader mechanisms in medical devices: A review on scientific and patent literature | |
| JP2021020092A (ja) | 操作可能な医療器具 | |
| Duan et al. | A survey of needle steering approaches in minimally invasive surgery | |
| Lu et al. | Flexible needle steering with tethered and untethered actuation: Current states, targeting errors, challenges and opportunities | |
| Li et al. | A novel endoscope design using spiral technique for robotic-assisted endoscopy insertion | |
| CN110177507A (zh) | 尖锐转弯的可转向针 | |
| Kwon et al. | A steerable endoscope for transnasal skull base surgery | |
| US12369884B2 (en) | Endoluminal shafts including ultrasound coupling capability | |
| Wang et al. | Bio-Inspired Pupal-Mode Actuator with Ultra-Crossing Capability for Soft Robots | |
| Rox | Mechanical and Computational Design of Continuum Robots for Minimally Invasive Lung Interventions | |
| Al Falahi | Force and Stiffness Control of Continuum Robots for Minimally Invasive Cardiac Surgery | |
| Liu | Multidirectional Bending Robotic Device Using SMA Wires for Precise Laser Irradiation During Transurethral Lithotripsy |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| A977 | Report on retrieval |
Free format text: JAPANESE INTERMEDIATE CODE: A971007 Effective date: 20141218 |
|
| A131 | Notification of reasons for refusal |
Free format text: JAPANESE INTERMEDIATE CODE: A131 Effective date: 20150106 |
|
| A601 | Written request for extension of time |
Free format text: JAPANESE INTERMEDIATE CODE: A601 Effective date: 20150402 |
|
| A521 | Request for written amendment filed |
Free format text: JAPANESE INTERMEDIATE CODE: A523 Effective date: 20150507 |
|
| A02 | Decision of refusal |
Free format text: JAPANESE INTERMEDIATE CODE: A02 Effective date: 20151104 |
|
| A521 | Request for written amendment filed |
Free format text: JAPANESE INTERMEDIATE CODE: A523 Effective date: 20160302 |
|
| A911 | Transfer to examiner for re-examination before appeal (zenchi) |
Free format text: JAPANESE INTERMEDIATE CODE: A911 Effective date: 20160316 |
|
| TRDD | Decision of grant or rejection written | ||
| A01 | Written decision to grant a patent or to grant a registration (utility model) |
Free format text: JAPANESE INTERMEDIATE CODE: A01 Effective date: 20160531 |
|
| A61 | First payment of annual fees (during grant procedure) |
Free format text: JAPANESE INTERMEDIATE CODE: A61 Effective date: 20160629 |
|
| R150 | Certificate of patent or registration of utility model |
Ref document number: 5964335 Country of ref document: JP Free format text: JAPANESE INTERMEDIATE CODE: R150 |
|
| R250 | Receipt of annual fees |
Free format text: JAPANESE INTERMEDIATE CODE: R250 |
|
| R250 | Receipt of annual fees |
Free format text: JAPANESE INTERMEDIATE CODE: R250 |
|
| R250 | Receipt of annual fees |
Free format text: JAPANESE INTERMEDIATE CODE: R250 |
|
| R250 | Receipt of annual fees |
Free format text: JAPANESE INTERMEDIATE CODE: R250 |
|
| R250 | Receipt of annual fees |
Free format text: JAPANESE INTERMEDIATE CODE: R250 |
|
| R250 | Receipt of annual fees |
Free format text: JAPANESE INTERMEDIATE CODE: R250 |
|
| R250 | Receipt of annual fees |
Free format text: JAPANESE INTERMEDIATE CODE: R250 |