JP2019196909A - 感圧装置、ハンドおよびロボット - Google Patents
感圧装置、ハンドおよびロボット Download PDFInfo
- Publication number
- JP2019196909A JP2019196909A JP2018089079A JP2018089079A JP2019196909A JP 2019196909 A JP2019196909 A JP 2019196909A JP 2018089079 A JP2018089079 A JP 2018089079A JP 2018089079 A JP2018089079 A JP 2018089079A JP 2019196909 A JP2019196909 A JP 2019196909A
- Authority
- JP
- Japan
- Prior art keywords
- pressure
- resin mixture
- resin
- substrate
- sensitive device
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Withdrawn
Links
Images







Classifications
-
- H—ELECTRICITY
- H01—ELECTRIC ELEMENTS
- H01C—RESISTORS
- H01C10/00—Adjustable resistors
- H01C10/10—Adjustable resistors adjustable by mechanical pressure or force
- H01C10/12—Adjustable resistors adjustable by mechanical pressure or force by changing surface pressure between resistive masses or resistive and conductive masses, e.g. pile type
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B25—HAND TOOLS; PORTABLE POWER-DRIVEN TOOLS; MANIPULATORS
- B25J—MANIPULATORS; CHAMBERS PROVIDED WITH MANIPULATION DEVICES
- B25J13/00—Controls for manipulators
- B25J13/08—Controls for manipulators by means of sensing devices, e.g. viewing or touching devices
- B25J13/081—Touching devices, e.g. pressure-sensitive
- B25J13/082—Grasping-force detectors
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B25—HAND TOOLS; PORTABLE POWER-DRIVEN TOOLS; MANIPULATORS
- B25J—MANIPULATORS; CHAMBERS PROVIDED WITH MANIPULATION DEVICES
- B25J19/00—Accessories fitted to manipulators, e.g. for monitoring, for viewing; Safety devices combined with or specially adapted for use in connection with manipulators
- B25J19/02—Sensing devices
- B25J19/028—Piezoresistive or piezoelectric sensing devices
-
- G—PHYSICS
- G01—MEASURING; TESTING
- G01L—MEASURING FORCE, STRESS, TORQUE, WORK, MECHANICAL POWER, MECHANICAL EFFICIENCY, OR FLUID PRESSURE
- G01L5/00—Apparatus for, or methods of, measuring force, work, mechanical power, or torque, specially adapted for specific purposes
-
- H—ELECTRICITY
- H01—ELECTRIC ELEMENTS
- H01C—RESISTORS
- H01C1/00—Details
- H01C1/01—Mounting; Supporting
- H01C1/014—Mounting; Supporting the resistor being suspended between and being supported by two supporting sections
-
- H—ELECTRICITY
- H01—ELECTRIC ELEMENTS
- H01C—RESISTORS
- H01C1/00—Details
- H01C1/14—Terminals or tapping points specially adapted for resistors; Arrangements of terminals or tapping points on resistors
-
- H—ELECTRICITY
- H01—ELECTRIC ELEMENTS
- H01C—RESISTORS
- H01C10/00—Adjustable resistors
- H01C10/10—Adjustable resistors adjustable by mechanical pressure or force
- H01C10/106—Adjustable resistors adjustable by mechanical pressure or force on resistive material dispersed in an elastic material
-
- H—ELECTRICITY
- H01—ELECTRIC ELEMENTS
- H01C—RESISTORS
- H01C17/00—Apparatus or processes specially adapted for manufacturing resistors
- H01C17/06—Apparatus or processes specially adapted for manufacturing resistors adapted for coating resistive material on a base
- H01C17/065—Apparatus or processes specially adapted for manufacturing resistors adapted for coating resistive material on a base by thick film techniques, e.g. serigraphy
- H01C17/06506—Precursor compositions therefor, e.g. pastes, inks, glass frits or green body
- H01C17/06513—Precursor compositions therefor, e.g. pastes, inks, glass frits or green body characterised by the resistive component
- H01C17/0652—Precursor compositions therefor, e.g. pastes, inks, glass frits or green body characterised by the resistive component containing carbon or carbides
-
- H—ELECTRICITY
- H01—ELECTRIC ELEMENTS
- H01C—RESISTORS
- H01C17/00—Apparatus or processes specially adapted for manufacturing resistors
- H01C17/06—Apparatus or processes specially adapted for manufacturing resistors adapted for coating resistive material on a base
- H01C17/065—Apparatus or processes specially adapted for manufacturing resistors adapted for coating resistive material on a base by thick film techniques, e.g. serigraphy
- H01C17/06506—Precursor compositions therefor, e.g. pastes, inks, glass frits or green body
- H01C17/06573—Precursor compositions therefor, e.g. pastes, inks, glass frits or green body characterised by the permanent binder
- H01C17/06586—Precursor compositions therefor, e.g. pastes, inks, glass frits or green body characterised by the permanent binder composed of organic material
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B82—NANOTECHNOLOGY
- B82Y—SPECIFIC USES OR APPLICATIONS OF NANOSTRUCTURES; MEASUREMENT OR ANALYSIS OF NANOSTRUCTURES; MANUFACTURE OR TREATMENT OF NANOSTRUCTURES
- B82Y30/00—Nanotechnology for materials or surface science, e.g. nanocomposites
-
- Y—GENERAL TAGGING OF NEW TECHNOLOGICAL DEVELOPMENTS; GENERAL TAGGING OF CROSS-SECTIONAL TECHNOLOGIES SPANNING OVER SEVERAL SECTIONS OF THE IPC; TECHNICAL SUBJECTS COVERED BY FORMER USPC CROSS-REFERENCE ART COLLECTIONS [XRACs] AND DIGESTS
- Y10—TECHNICAL SUBJECTS COVERED BY FORMER USPC
- Y10S—TECHNICAL SUBJECTS COVERED BY FORMER USPC CROSS-REFERENCE ART COLLECTIONS [XRACs] AND DIGESTS
- Y10S977/00—Nanotechnology
- Y10S977/70—Nanostructure
- Y10S977/734—Fullerenes, i.e. graphene-based structures, such as nanohorns, nanococoons, nanoscrolls or fullerene-like structures, e.g. WS2 or MoS2 chalcogenide nanotubes, planar C3N4, etc.
- Y10S977/742—Carbon nanotubes, CNTs
Landscapes
- Engineering & Computer Science (AREA)
- Microelectronics & Electronic Packaging (AREA)
- Robotics (AREA)
- Mechanical Engineering (AREA)
- Human Computer Interaction (AREA)
- Manufacturing & Machinery (AREA)
- Physics & Mathematics (AREA)
- General Physics & Mathematics (AREA)
- Chemical & Material Sciences (AREA)
- Dispersion Chemistry (AREA)
- Force Measurement Appropriate To Specific Purposes (AREA)
Abstract
Description
前記樹脂混合物に積層されている電極と、
前記積層方向に前記樹脂混合物を与圧する与圧部と、を有し、
前記与圧部は、前記与圧量を調整する調整機構を備えることを特徴とする。
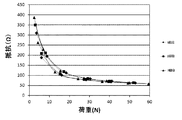
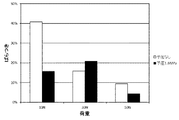
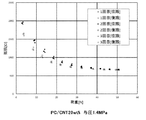
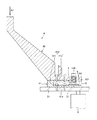
図1は、本発明の第1実施形態に係る感圧装置の断面図である。図2は、感圧装置の荷重−抵抗特性を示すグラフである。図3は、与圧しなかった場合の荷重−抵抗特性を示すグラフである。図4は、与圧した場合の荷重−抵抗特性を示すグラフである。図5は、与圧した場合としなかった場合との測定値ばらつきを示すグラフである。図6ないし図9は、それぞれ、樹脂としてPCを用いた場合の荷重−抵抗特性を示すグラフである。図10は、樹脂としてPCを用いた場合の測定値ばらつきを示すグラフである。図11ないし図14は、それぞれ、樹脂としてPPを用いた場合の荷重−抵抗特性を示すグラフである。図15は、樹脂としてPPを用いた場合の測定値ばらつきを示すグラフである。図16ないし図19は、それぞれ、樹脂としてPETを用いた場合の荷重−抵抗特性を示すグラフである。図20は、樹脂としてPETを用いた場合の測定値ばらつきを示すグラフである。なお、以下では、説明の便宜上、図1中の上側を「上」とも言い、下側を「下」とも言う。
図21は、本発明の第2実施形態に係るハンドを示す平面図である。図22は、図21に示すハンドが有する指部の断面図である。図23は、図22に示す指部に配置された感圧装置の断面図である。図24および図25は、それぞれ、感圧装置が荷重を検知する仕組みを説明するための断面図である。
次に、本発明の第3実施形態に係るロボットについて説明する。
図26は、本発明の第3実施形態に係るロボットを示す斜視図である。
Claims (11)
- カーボンナノチューブが混合されている樹脂混合物と、
前記樹脂混合物に積層されている電極と、
前記積層方向に前記樹脂混合物を与圧する与圧部と、を有し、
前記与圧部は、前記与圧量を調整する調整機構を備えることを特徴とする感圧装置。 - 前記与圧部は、第1基板、前記第1基板と積層する方向に沿って配置されている第2基板、および前記調整機構であるねじ、を有し、
前記ねじの回転により、前記第1基板と前記第2基板との間の距離が変化することで、前記与圧量が調整される請求項1に記載の感圧装置。 - 前記カーボンナノチューブは、直径が100nm以上200nm以下の範囲内にあり、長さが2μm以上10μm以下の範囲内にある請求項1または2に記載の感圧装置。
- 前記樹脂混合物中の前記カーボンナノチューブの含有率は、2wt%以上30wt%以下の範囲内にある請求項1ないし3のいずれか1項に記載の感圧装置。
- 前記樹脂は、ポリカーボネートを含む請求項1ないし4のいずれか1項に記載の感圧装置。
- 前記樹脂は、ポリプロピレン、ポリエチレンテレフタレートおよびポリフェニレンサルファイドのいずれかを含む請求項1ないし4のいずれか1項に記載の感圧装置。
- 前記樹脂混合物は、シート状をなし、
前記樹脂混合物の厚さが50μm以上200μm以下の範囲内にある請求項1ないし6のいずれか1項に記載の感圧装置。 - 前記与圧は、1MPa以上15MPa以下の範囲内にある請求項1ないし7のいずれか1項に記載の感圧装置。
- 前記樹脂混合物のヤング率は、前記樹脂のヤング率の1.5倍以上2倍以下の範囲内にある請求項1ないし8のいずれか1項に記載の感圧装置。
- 請求項1ないし9のいずれか1項に記載の感圧装置を有することを特徴とするハンド。
- 請求項1ないし9のいずれか1項に記載の感圧装置を有することを特徴とするロボット。
Priority Applications (3)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| JP2018089079A JP2019196909A (ja) | 2018-05-07 | 2018-05-07 | 感圧装置、ハンドおよびロボット |
| CN201910371481.XA CN110450194A (zh) | 2018-05-07 | 2019-05-06 | 压敏装置、手部以及机器人 |
| US16/403,733 US20190341176A1 (en) | 2018-05-07 | 2019-05-06 | Pressure-sensitive device, hand, and robot |
Applications Claiming Priority (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| JP2018089079A JP2019196909A (ja) | 2018-05-07 | 2018-05-07 | 感圧装置、ハンドおよびロボット |
Publications (2)
| Publication Number | Publication Date |
|---|---|
| JP2019196909A true JP2019196909A (ja) | 2019-11-14 |
| JP2019196909A5 JP2019196909A5 (ja) | 2021-04-15 |
Family
ID=68385165
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| JP2018089079A Withdrawn JP2019196909A (ja) | 2018-05-07 | 2018-05-07 | 感圧装置、ハンドおよびロボット |
Country Status (3)
| Country | Link |
|---|---|
| US (1) | US20190341176A1 (ja) |
| JP (1) | JP2019196909A (ja) |
| CN (1) | CN110450194A (ja) |
Families Citing this family (1)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| LU502264B1 (en) * | 2022-06-14 | 2023-12-14 | Helion Energy Inc | High-Energy Particulate Resistors |
Citations (4)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JPS6288929U (ja) * | 1985-11-26 | 1987-06-06 | ||
| JP2015169617A (ja) * | 2014-03-10 | 2015-09-28 | 日立化成株式会社 | 抵抗型感圧センサ用導電性樹脂組成物及び抵抗型感圧センサ |
| US20170153153A1 (en) * | 2015-12-01 | 2017-06-01 | Sensitronics, LLC | Metalized polyester film force sensors |
| US20180117772A1 (en) * | 2016-10-31 | 2018-05-03 | Seiko Epson Corporation | Hand and robot |
Family Cites Families (16)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JP4429142B2 (ja) * | 2004-11-10 | 2010-03-10 | 本田技研工業株式会社 | 固体高分子型燃料電池の電極構造体 |
| US20070078484A1 (en) * | 2005-10-03 | 2007-04-05 | Joseph Talarico | Gentle touch surgical instrument and method of using same |
| US20070074584A1 (en) * | 2005-10-03 | 2007-04-05 | Joseph Talarico | Gentle touch surgical instrument and method of using same |
| WO2008064215A2 (en) * | 2006-11-20 | 2008-05-29 | Sabic Innovative Plastics Ip Bv | Thermally regulated electrically conducting compositions |
| US20090277608A1 (en) * | 2008-05-07 | 2009-11-12 | Kamins Theodore I | Thermal Control Via Adjustable Thermal Links |
| US8020456B2 (en) * | 2008-05-30 | 2011-09-20 | Florida State University Research Foundation | Sensor and a method of making a sensor |
| EP2433315A1 (en) * | 2009-05-22 | 2012-03-28 | University of New Brunswick | Force sensing compositions, devices and methods |
| US9099224B2 (en) * | 2009-10-01 | 2015-08-04 | Board Of Supervisors Of Louisiana State University And Agricultural And Mechanical College | Apparatus and method for nanocomposite sensors |
| US8643463B2 (en) * | 2009-11-30 | 2014-02-04 | Nanyang Polytechnic | Porous film sensor |
| CN104869969B (zh) * | 2012-09-17 | 2017-06-09 | 哈佛大学校长及研究员协会 | 用于辅助人类运动的软式外装护具 |
| JP6378533B2 (ja) * | 2013-06-01 | 2018-08-22 | 日東電工株式会社 | 熱伝導性粘着シート |
| CN104596675B (zh) * | 2013-10-31 | 2019-05-14 | 精工爱普生株式会社 | 传感器元件、力检测装置、机器人、电子部件输送装置 |
| US20170350772A1 (en) * | 2014-12-23 | 2017-12-07 | Haydale Graphene Industries Plc | Piezoresistive Device |
| JP2017010933A (ja) * | 2015-06-19 | 2017-01-12 | 株式会社半導体エネルギー研究所 | 蓄電装置の充電方法及び蓄電装置の製造方法、並びにバッテリーモジュール及び車両 |
| US10327343B2 (en) * | 2015-12-09 | 2019-06-18 | International Business Machines Corporation | Applying pressure to adhesive using CTE mismatch between components |
| JP7149699B2 (ja) * | 2017-11-01 | 2022-10-07 | 日東電工株式会社 | 熱伝導性粘着シート |
-
2018
- 2018-05-07 JP JP2018089079A patent/JP2019196909A/ja not_active Withdrawn
-
2019
- 2019-05-06 CN CN201910371481.XA patent/CN110450194A/zh active Pending
- 2019-05-06 US US16/403,733 patent/US20190341176A1/en not_active Abandoned
Patent Citations (4)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JPS6288929U (ja) * | 1985-11-26 | 1987-06-06 | ||
| JP2015169617A (ja) * | 2014-03-10 | 2015-09-28 | 日立化成株式会社 | 抵抗型感圧センサ用導電性樹脂組成物及び抵抗型感圧センサ |
| US20170153153A1 (en) * | 2015-12-01 | 2017-06-01 | Sensitronics, LLC | Metalized polyester film force sensors |
| US20180117772A1 (en) * | 2016-10-31 | 2018-05-03 | Seiko Epson Corporation | Hand and robot |
Also Published As
| Publication number | Publication date |
|---|---|
| US20190341176A1 (en) | 2019-11-07 |
| CN110450194A (zh) | 2019-11-15 |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| US5583476A (en) | Flexible potentiometer | |
| US7642696B2 (en) | Vibration actuator and drive unit including the same | |
| US7952038B1 (en) | Two-stage switch apparatus | |
| US20110048139A1 (en) | Micro-deformable piezoresistive material and manufacturing method thereof and pressure sensor using the same | |
| US20170059432A1 (en) | Double-acting pressure sensor | |
| US20090235760A1 (en) | Load sensor and manufacturing method for the same | |
| CN108015789A (zh) | 手及机器人 | |
| JP2018069385A (ja) | ハンドおよびロボット | |
| KR102325435B1 (ko) | 유연인쇄회로기판상 유연센서 접합방법, 및 유연센서가 접합된 유연센서인쇄회로기판 | |
| US9972768B2 (en) | Actuator structure and method | |
| WO2009057582A1 (ja) | 電気的接続体及びその製造方法 | |
| US12133326B2 (en) | Extensible and contractible wiring board and method for manufacturing extensible and contractible wiring board | |
| JP5658951B2 (ja) | 感圧センサー | |
| TWI679405B (zh) | 感壓傳感器 | |
| US20190341176A1 (en) | Pressure-sensitive device, hand, and robot | |
| JP4609637B2 (ja) | ペダル踏力検出装置 | |
| US20190184578A1 (en) | Grasping Hand And Robot | |
| US20230160762A1 (en) | Pressure Sensing Element with Porous Structure Based Flexible Base | |
| JP7183700B2 (ja) | 感圧センサーおよびハンド | |
| CN117288354B (zh) | 一种压力传感器 | |
| JP2003045262A (ja) | メンブレン型感圧シートおよびその製造方法 | |
| KR102093697B1 (ko) | 임피던스 측정을 이용한 센서 및 그 센싱방법 | |
| CN115530902A (zh) | 吻合器 | |
| US20230008926A1 (en) | Sensor | |
| US8681117B2 (en) | Flexible slide-touch controlling device and the related position determination method |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| RD05 | Notification of revocation of power of attorney |
Free format text: JAPANESE INTERMEDIATE CODE: A7425 Effective date: 20180910 |
|
| RD03 | Notification of appointment of power of attorney |
Free format text: JAPANESE INTERMEDIATE CODE: A7423 Effective date: 20181121 |
|
| RD07 | Notification of extinguishment of power of attorney |
Free format text: JAPANESE INTERMEDIATE CODE: A7427 Effective date: 20200810 |
|
| A521 | Request for written amendment filed |
Free format text: JAPANESE INTERMEDIATE CODE: A523 Effective date: 20210305 |
|
| A621 | Written request for application examination |
Free format text: JAPANESE INTERMEDIATE CODE: A621 Effective date: 20210305 |
|
| RD04 | Notification of resignation of power of attorney |
Free format text: JAPANESE INTERMEDIATE CODE: A7424 Effective date: 20210917 |
|
| RD03 | Notification of appointment of power of attorney |
Free format text: JAPANESE INTERMEDIATE CODE: A7423 Effective date: 20211108 |
|
| A977 | Report on retrieval |
Free format text: JAPANESE INTERMEDIATE CODE: A971007 Effective date: 20211228 |
|
| A131 | Notification of reasons for refusal |
Free format text: JAPANESE INTERMEDIATE CODE: A131 Effective date: 20220106 |
|
| A761 | Written withdrawal of application |
Free format text: JAPANESE INTERMEDIATE CODE: A761 Effective date: 20220307 |