JP6033436B2 - 位置検出センサおよびマニピュレータ - Google Patents
位置検出センサおよびマニピュレータ Download PDFInfo
- Publication number
- JP6033436B2 JP6033436B2 JP2015525331A JP2015525331A JP6033436B2 JP 6033436 B2 JP6033436 B2 JP 6033436B2 JP 2015525331 A JP2015525331 A JP 2015525331A JP 2015525331 A JP2015525331 A JP 2015525331A JP 6033436 B2 JP6033436 B2 JP 6033436B2
- Authority
- JP
- Japan
- Prior art keywords
- conductive
- contact member
- detection sensor
- position detection
- contact
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Active
Links
Images











Classifications
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B25—HAND TOOLS; PORTABLE POWER-DRIVEN TOOLS; MANIPULATORS
- B25J—MANIPULATORS; CHAMBERS PROVIDED WITH MANIPULATION DEVICES
- B25J13/00—Controls for manipulators
- B25J13/08—Controls for manipulators by means of sensing devices, e.g. viewing or touching devices
- B25J13/088—Controls for manipulators by means of sensing devices, e.g. viewing or touching devices with position, velocity or acceleration sensors
-
- A—HUMAN NECESSITIES
- A61—MEDICAL OR VETERINARY SCIENCE; HYGIENE
- A61B—DIAGNOSIS; SURGERY; IDENTIFICATION
- A61B34/00—Computer-aided surgery; Manipulators or robots specially adapted for use in surgery
- A61B34/20—Surgical navigation systems; Devices for tracking or guiding surgical instruments, e.g. for frameless stereotaxis
-
- A—HUMAN NECESSITIES
- A61—MEDICAL OR VETERINARY SCIENCE; HYGIENE
- A61B—DIAGNOSIS; SURGERY; IDENTIFICATION
- A61B34/00—Computer-aided surgery; Manipulators or robots specially adapted for use in surgery
- A61B34/30—Surgical robots
-
- A—HUMAN NECESSITIES
- A61—MEDICAL OR VETERINARY SCIENCE; HYGIENE
- A61B—DIAGNOSIS; SURGERY; IDENTIFICATION
- A61B34/00—Computer-aided surgery; Manipulators or robots specially adapted for use in surgery
- A61B34/30—Surgical robots
- A61B34/35—Surgical robots for telesurgery
-
- A—HUMAN NECESSITIES
- A61—MEDICAL OR VETERINARY SCIENCE; HYGIENE
- A61B—DIAGNOSIS; SURGERY; IDENTIFICATION
- A61B34/00—Computer-aided surgery; Manipulators or robots specially adapted for use in surgery
- A61B34/30—Surgical robots
- A61B34/37—Leader-follower robots
-
- G—PHYSICS
- G01—MEASURING; TESTING
- G01D—MEASURING NOT SPECIALLY ADAPTED FOR A SPECIFIC VARIABLE; ARRANGEMENTS FOR MEASURING TWO OR MORE VARIABLES NOT COVERED IN A SINGLE OTHER SUBCLASS; TARIFF METERING APPARATUS; MEASURING OR TESTING NOT OTHERWISE PROVIDED FOR
- G01D5/00—Mechanical means for transferring the output of a sensing member; Means for converting the output of a sensing member to another variable where the form or nature of the sensing member does not constrain the means for converting; Transducers not specially adapted for a specific variable
- G01D5/12—Mechanical means for transferring the output of a sensing member; Means for converting the output of a sensing member to another variable where the form or nature of the sensing member does not constrain the means for converting; Transducers not specially adapted for a specific variable using electric or magnetic means
- G01D5/14—Mechanical means for transferring the output of a sensing member; Means for converting the output of a sensing member to another variable where the form or nature of the sensing member does not constrain the means for converting; Transducers not specially adapted for a specific variable using electric or magnetic means influencing the magnitude of a current or voltage
- G01D5/16—Mechanical means for transferring the output of a sensing member; Means for converting the output of a sensing member to another variable where the form or nature of the sensing member does not constrain the means for converting; Transducers not specially adapted for a specific variable using electric or magnetic means influencing the magnitude of a current or voltage by varying resistance
- G01D5/165—Mechanical means for transferring the output of a sensing member; Means for converting the output of a sensing member to another variable where the form or nature of the sensing member does not constrain the means for converting; Transducers not specially adapted for a specific variable using electric or magnetic means influencing the magnitude of a current or voltage by varying resistance by relative movement of a point of contact or actuation and a resistive track
-
- G—PHYSICS
- G01—MEASURING; TESTING
- G01D—MEASURING NOT SPECIALLY ADAPTED FOR A SPECIFIC VARIABLE; ARRANGEMENTS FOR MEASURING TWO OR MORE VARIABLES NOT COVERED IN A SINGLE OTHER SUBCLASS; TARIFF METERING APPARATUS; MEASURING OR TESTING NOT OTHERWISE PROVIDED FOR
- G01D5/00—Mechanical means for transferring the output of a sensing member; Means for converting the output of a sensing member to another variable where the form or nature of the sensing member does not constrain the means for converting; Transducers not specially adapted for a specific variable
- G01D5/12—Mechanical means for transferring the output of a sensing member; Means for converting the output of a sensing member to another variable where the form or nature of the sensing member does not constrain the means for converting; Transducers not specially adapted for a specific variable using electric or magnetic means
- G01D5/244—Mechanical means for transferring the output of a sensing member; Means for converting the output of a sensing member to another variable where the form or nature of the sensing member does not constrain the means for converting; Transducers not specially adapted for a specific variable using electric or magnetic means influencing characteristics of pulses or pulse trains; generating pulses or pulse trains
- G01D5/245—Mechanical means for transferring the output of a sensing member; Means for converting the output of a sensing member to another variable where the form or nature of the sensing member does not constrain the means for converting; Transducers not specially adapted for a specific variable using electric or magnetic means influencing characteristics of pulses or pulse trains; generating pulses or pulse trains using a variable number of pulses in a train
- G01D5/2451—Incremental encoders
-
- A—HUMAN NECESSITIES
- A61—MEDICAL OR VETERINARY SCIENCE; HYGIENE
- A61B—DIAGNOSIS; SURGERY; IDENTIFICATION
- A61B17/00—Surgical instruments, devices or methods
- A61B2017/00526—Methods of manufacturing
-
- A—HUMAN NECESSITIES
- A61—MEDICAL OR VETERINARY SCIENCE; HYGIENE
- A61B—DIAGNOSIS; SURGERY; IDENTIFICATION
- A61B17/00—Surgical instruments, devices or methods
- A61B2017/00831—Material properties
- A61B2017/00929—Material properties isolating electrical current
-
- A—HUMAN NECESSITIES
- A61—MEDICAL OR VETERINARY SCIENCE; HYGIENE
- A61B—DIAGNOSIS; SURGERY; IDENTIFICATION
- A61B34/00—Computer-aided surgery; Manipulators or robots specially adapted for use in surgery
- A61B34/20—Surgical navigation systems; Devices for tracking or guiding surgical instruments, e.g. for frameless stereotaxis
- A61B2034/2046—Tracking techniques
- A61B2034/2059—Mechanical position encoders
-
- A—HUMAN NECESSITIES
- A61—MEDICAL OR VETERINARY SCIENCE; HYGIENE
- A61B—DIAGNOSIS; SURGERY; IDENTIFICATION
- A61B34/00—Computer-aided surgery; Manipulators or robots specially adapted for use in surgery
- A61B34/20—Surgical navigation systems; Devices for tracking or guiding surgical instruments, e.g. for frameless stereotaxis
- A61B2034/2046—Tracking techniques
- A61B2034/2061—Tracking techniques using shape-sensors, e.g. fiber shape sensors with Bragg gratings
-
- F—MECHANICAL ENGINEERING; LIGHTING; HEATING; WEAPONS; BLASTING
- F04—POSITIVE - DISPLACEMENT MACHINES FOR LIQUIDS; PUMPS FOR LIQUIDS OR ELASTIC FLUIDS
- F04C—ROTARY-PISTON, OR OSCILLATING-PISTON, POSITIVE-DISPLACEMENT MACHINES FOR LIQUIDS; ROTARY-PISTON, OR OSCILLATING-PISTON, POSITIVE-DISPLACEMENT PUMPS
- F04C2270/00—Control; Monitoring or safety arrangements
- F04C2270/04—Force
- F04C2270/042—Force radial
- F04C2270/0421—Controlled or regulated
-
- G—PHYSICS
- G01—MEASURING; TESTING
- G01D—MEASURING NOT SPECIALLY ADAPTED FOR A SPECIFIC VARIABLE; ARRANGEMENTS FOR MEASURING TWO OR MORE VARIABLES NOT COVERED IN A SINGLE OTHER SUBCLASS; TARIFF METERING APPARATUS; MEASURING OR TESTING NOT OTHERWISE PROVIDED FOR
- G01D5/00—Mechanical means for transferring the output of a sensing member; Means for converting the output of a sensing member to another variable where the form or nature of the sensing member does not constrain the means for converting; Transducers not specially adapted for a specific variable
- G01D5/12—Mechanical means for transferring the output of a sensing member; Means for converting the output of a sensing member to another variable where the form or nature of the sensing member does not constrain the means for converting; Transducers not specially adapted for a specific variable using electric or magnetic means
- G01D5/244—Mechanical means for transferring the output of a sensing member; Means for converting the output of a sensing member to another variable where the form or nature of the sensing member does not constrain the means for converting; Transducers not specially adapted for a specific variable using electric or magnetic means influencing characteristics of pulses or pulse trains; generating pulses or pulse trains
- G01D5/245—Mechanical means for transferring the output of a sensing member; Means for converting the output of a sensing member to another variable where the form or nature of the sensing member does not constrain the means for converting; Transducers not specially adapted for a specific variable using electric or magnetic means influencing characteristics of pulses or pulse trains; generating pulses or pulse trains using a variable number of pulses in a train
- G01D5/2454—Encoders incorporating incremental and absolute signals
- G01D5/2455—Encoders incorporating incremental and absolute signals with incremental and absolute tracks on the same encoder
- G01D5/2457—Incremental encoders having reference marks
Landscapes
- Health & Medical Sciences (AREA)
- Engineering & Computer Science (AREA)
- Life Sciences & Earth Sciences (AREA)
- Surgery (AREA)
- Robotics (AREA)
- Animal Behavior & Ethology (AREA)
- Public Health (AREA)
- Heart & Thoracic Surgery (AREA)
- Medical Informatics (AREA)
- Molecular Biology (AREA)
- Nuclear Medicine, Radiotherapy & Molecular Imaging (AREA)
- General Health & Medical Sciences (AREA)
- Biomedical Technology (AREA)
- Veterinary Medicine (AREA)
- Physics & Mathematics (AREA)
- General Physics & Mathematics (AREA)
- Human Computer Interaction (AREA)
- Mechanical Engineering (AREA)
- Manipulator (AREA)
- Measurement Of Length, Angles, Or The Like Using Electric Or Magnetic Means (AREA)
- Transmission And Conversion Of Sensor Element Output (AREA)
Description
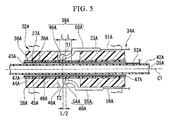
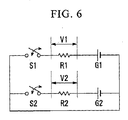
以下、本発明の第1実施形態に係る位置検出センサ、およびマニピュレータを備えるマニピュレータシステムを、図1から図16を参照しながら説明する。
本発明の第2実施形態について図19を参照しながら説明する。本実施形態において前記実施形態と同一の部位には同一の符号を付してその説明は省略し、異なる点についてのみ説明する。
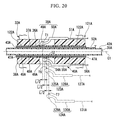
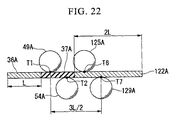
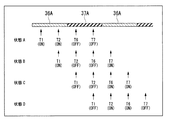
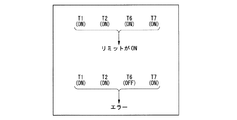
本発明の第3実施形態について図20から図24を参照しながら説明する。本実施形態において前記実施形態と同一の部位には同一の符号を付してその説明は省略し、異なる点についてのみ説明する。
本発明の第4実施形態について図25を参照しながら説明する。本実施形態において前記実施形態と同一の部位には同一の符号を付してその説明は省略し、異なる点についてのみ説明する。
本発明の第5実施形態について図26を参照しながら説明する。本実施形態において前記実施形態と同一の部位には同一の符号を付してその説明は省略し、異なる点についてのみ説明する。
L1+2L3=L2 ・・・(2)
本発明の第6実施形態について図28から図32を参照しながら説明する。本実施形態において、前記実施形態と同一の部位には同一の符号を付してその説明は省略し、異なる点についてのみ説明する。
本発明の第7実施形態について図33から図35を参照しながら説明する。本実施形態において前記実施形態と同一の部位には同一の符号を付してその説明は省略し、異なる点についてのみ説明する。
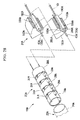
34A、101A、121A、136A、141A、184A、290A 位置検出センサ
35A 操作ワイヤ(線状部材)
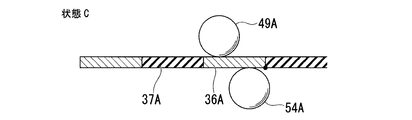
36A 導電リング(導電部)
37A 絶縁リング(絶縁部)
38A、144A、193A、291A 支持部材
49A、102A、214A 第一の接触部材(接触部材)
54A、103A、219A 第二の接触部材(接触部材)
Claims (11)
- 線状部材と、
前記線状部材の外周面に設けられるとともに、前記線状部材の軸線方向に並べて配置された導電部および絶縁部と、
前記導電部および前記絶縁部に対して前記軸線方向に相対的に進退可能に設けられた絶縁性の支持部材と、
前記支持部材に取付けられ、前記導電部および前記絶縁部の外面に向かう付勢力により、前記導電部および前記絶縁部の前記外面に自身の先端が接触するように構成された導電性の接触部材と、
前記導電部および前記絶縁部と前記線状部材との間に設けられ、前記導電部に電気的に接続された導電性の管状部材と、
を備え、
前記導電部は、複数設けられ、
前記絶縁部は、前記軸線方向に隣り合う前記複数の導電部の間に配置され、
前記複数の導電部の各々の前記軸線方向の長さと前記絶縁部の前記軸線方向の長さとは、互いにおおむね等しく設定されている
位置検出センサ。 - 請求項1に記載の位置検出センサであって、
前記複数の導電部および前記絶縁部が、前記線状部材の全周にわたり設けられている
位置検出センサ。 - 請求項1または2に記載の位置検出センサであって、
前記付勢力を発生するように構成された第一の付勢部材と、
前記付勢力を発生するように構成された第二の付勢部材と、
前記第一の付勢部材および前記第二の付勢部材を保持するように構成された保持部材と、
前記保持部材に対して前記第一の付勢部材および前記第二の付勢部材を固定するように構成された固定部と、
をさらに備え、
前記第一の付勢部材および前記第二の付勢部材は、前記保持部材とともに前記支持部材に取り付けられ、
前記接触部材は、前記第一の付勢部材に取り付けられた第一の接触部材と、前記第二の付勢部材に取り付けられた第二の接触部材とを備え、
前記絶縁部は、複数設けられ、
前記複数の導電部および前記複数の絶縁部の各々は、前記軸線方向に交互に配置され、
前記保持部材は、前記軸線方向において、前記第二の接触部材が前記複数の導電部または前記複数の絶縁部に接触する位置と、前記第一の接触部材が前記複数の導電部または前記複数の絶縁部に接触する位置とが所定の距離となるように、前記第一の付勢部材および前記第二の付勢部材を保持している
位置検出センサ。 - 請求項3に記載の位置検出センサであって、
前記保持部材には、前記軸線方向に延びて前記第一の付勢部材を挿通可能とする第一の保持孔が形成され、
前記第一の保持孔は、前記第一の保持孔内で前記第一の付勢部材が自身の長手方向周りに回動することを防止するように構成された回動防止部を備える
位置検出センサ。 - 請求項3または4に記載の位置検出センサであって、
前記複数の導電部の各々の前記軸線方向の長さと前記複数の絶縁部の各々の前記軸線方向の長さとは互いに等しく、
前記軸線方向における前記複数の導電部の長さをL、自然数をNとしたときに、前記所定の距離は、L(N−1/2)の式により求められる値に等しい
位置検出センサ。 - 請求項1に記載の位置検出センサであって、
前記線状部材の外周面を覆う絶縁性の被覆材をさらに備え、
前記接触部材は、第一の接触部材と第二の接触部材とを備え、
前記第二の接触部材が前記複数の導電部または前記絶縁部に接触する位置は、前記第一の接触部材が前記複数の導電部または前記絶縁部に接触する位置よりも、前記軸線方向において前記複数の導電部の前記軸線方向の長さの半分だけずれている
位置検出センサ。 - 請求項1に記載の位置検出センサであって、
前記接触部材は、第一の接触部材と第二の接触部材とを備え、
前記線状部材は、導電性を有し、
前記線状部材と前記管状部材とは、電気的に接続され、
前記第二の接触部材が前記複数の導電部または前記絶縁部に接触する位置は、前記第一の接触部材が前記複数の導電部または前記絶縁部に接触する位置よりも、前記軸線方向において前記複数の導電部の前記軸線方向の長さの半分だけずれている
位置検出センサ。 - 請求項1に記載の位置検出センサであって、
前記接触部材は、球状に形成された第一の接触部材と、球状に形成された第二の接触部材とを備え、
前記第二の接触部材が前記複数の導電部または前記絶縁部に接触する位置は、前記第一の接触部材が前記複数の導電部または前記絶縁部に接触する位置よりも、前記軸線方向において前記複数の導電部の前記軸線方向の長さの半分だけずれている
位置検出センサ。 - 請求項1に記載の位置検出センサであって、
前記線状部材の軸線に向けて開口する凹部を有し、導電性の材料で形成された受け部材をさらに備え、
前記受け部材は、前記凹部内に前記接触部材を回転可能に支持するように構成されている
位置検出センサ。 - 請求項1に記載の位置検出センサであって、
前記軸線方向の長さが前記導電部の長さ以上に設定され、前記導電部および前記絶縁部と前記軸線方向に並べて配置された第二の導電部をさらに備え、
前記接触部材は、第一の接触部材と、第二の接触部材と、第三の接触部材と、第四の接触部材とを備え、
前記第二の接触部材が前記導電部、前記絶縁部、または第二の導電部に接触する位置は、前記第一の接触部材が前記導電部、前記絶縁部、または第二の導電部に接触する位置よりも、前記導電部の前記軸線方向の長さの半分だけ基端側にずれていて、
前記第三の接触部材が前記導電部、前記絶縁部、または第二の導電部に接触する位置は、前記第二の接触部材が前記導電部、前記絶縁部、または第二の導電部に接触する位置よりも、前記導電部の前記軸線方向の長さの半分だけ基端側にずれていて、
前記第四の接触部材が前記導電部、前記絶縁部、または第二の導電部に接触する位置は、前記第三の接触部材が前記導電部、前記絶縁部、または第二の導電部に接触する位置よりも、前記導電部の前記軸線方向の長さの半分だけ基端側にずれている
位置検出センサ。 - 請求項1から10のいずれか一項に記載の位置検出センサと、
前記支持部材に対して揺動可能に支持された揺動部材と、
を備え、
前記線状部材の先端部は、前記揺動部材に取り付けられている
マニピュレータ。
Applications Claiming Priority (5)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| US201261740010P | 2012-12-20 | 2012-12-20 | |
| US61/740,010 | 2012-12-20 | ||
| US201361766214P | 2013-02-19 | 2013-02-19 | |
| US61/766,214 | 2013-02-19 | ||
| PCT/JP2013/084394 WO2014098246A1 (en) | 2012-12-20 | 2013-12-17 | Position detection sensor and manipulator |
Publications (2)
| Publication Number | Publication Date |
|---|---|
| JP2015537187A JP2015537187A (ja) | 2015-12-24 |
| JP6033436B2 true JP6033436B2 (ja) | 2016-11-30 |
Family
ID=50978558
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| JP2015525331A Active JP6033436B2 (ja) | 2012-12-20 | 2013-12-17 | 位置検出センサおよびマニピュレータ |
Country Status (5)
| Country | Link |
|---|---|
| US (1) | US9802324B2 (ja) |
| EP (1) | EP2936070A4 (ja) |
| JP (1) | JP6033436B2 (ja) |
| CN (1) | CN104838238B (ja) |
| WO (1) | WO2014098246A1 (ja) |
Families Citing this family (9)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| WO2014098246A1 (en) * | 2012-12-20 | 2014-06-26 | Olympus Corporation | Position detection sensor and manipulator |
| JP6109440B2 (ja) * | 2015-02-25 | 2017-04-05 | オリンパス株式会社 | マニピュレータ |
| CN108697485B (zh) * | 2016-02-10 | 2021-06-08 | 奥林巴斯株式会社 | 操纵器系统 |
| US10285766B2 (en) * | 2017-03-29 | 2019-05-14 | Verb Surgical Inc. | Surgical table base construction for heat dissipation from housed power electronics |
| US12539195B2 (en) * | 2019-10-11 | 2026-02-03 | Bard Peripheral Vascular, Inc. | Electromagnetic tracking sensor having a flexible core, and methods for making same |
| CN112890955B (zh) * | 2021-01-18 | 2022-08-30 | 山东大学 | 一种经腔手术机器人操作臂系统、机器人及方法 |
| CN113397616B (zh) * | 2021-07-29 | 2022-09-06 | 天津瑞奇外科器械股份有限公司 | 一种外科器械 |
| CN113598955B (zh) * | 2021-09-13 | 2022-09-16 | 上海交通大学 | 一种微创手术机器人动力传递机构 |
| CN116549113B (zh) * | 2023-05-12 | 2024-05-03 | 北京长木谷医疗科技股份有限公司 | 一种手术机器人的智能光学定位系统 |
Family Cites Families (43)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| US2773995A (en) * | 1953-06-22 | 1956-12-11 | Lee M Griswold | System for converting mechanical movement into a related number of electrical pulses |
| JPS5940603U (ja) * | 1982-09-08 | 1984-03-15 | 三菱重工業株式会社 | 油圧シリンダ |
| JPH0132123Y2 (ja) * | 1985-03-12 | 1989-10-02 | ||
| US5873835A (en) * | 1993-04-29 | 1999-02-23 | Scimed Life Systems, Inc. | Intravascular pressure and flow sensor |
| US5572119A (en) * | 1994-10-28 | 1996-11-05 | Barber-Colman Company | Eddy current position sensor including an insulating base having conductive surfaces for electrically connecting a coil to the lead wires |
| JP2001510642A (ja) * | 1996-04-19 | 2001-07-31 | スポットズーム アクチーセルスカペット | テレビジョン画像内の物体の処理の方法と装置 |
| US6448759B2 (en) * | 1999-09-07 | 2002-09-10 | Bei Sensors And Systems Company, Inc. | Non-contact linear position sensor for motion control applications with inductive attenuating coupler |
| DE10025285A1 (de) * | 2000-05-22 | 2001-12-06 | Siemens Ag | Vollautomatische, robotergestützte Kameraführung unter Verwendung von Positionssensoren für laparoskopische Eingriffe |
| US6477396B1 (en) * | 2000-07-07 | 2002-11-05 | Biosense Webster, Inc. | Mapping and ablation catheter |
| DE10033723C1 (de) * | 2000-07-12 | 2002-02-21 | Siemens Ag | Visualisierung von Positionen und Orientierung von intrakorporal geführten Instrumenten während eines chirurgischen Eingriffs |
| JP2003161639A (ja) * | 2001-11-28 | 2003-06-06 | Denso Corp | 回転角度検出装置 |
| JP4268448B2 (ja) | 2002-05-21 | 2009-05-27 | 株式会社ミツトヨ | エンコーダ製造方法 |
| US6834439B2 (en) | 2002-05-21 | 2004-12-28 | Mitutoyo Corporation | Measuring tool, encoder and producing method of encoder |
| US10182734B2 (en) * | 2003-07-18 | 2019-01-22 | Biosense Webster, Inc. | Enhanced ablation and mapping catheter and method for treating atrial fibrillation |
| JP4494742B2 (ja) | 2003-09-12 | 2010-06-30 | ジーイー・メディカル・システムズ・グローバル・テクノロジー・カンパニー・エルエルシー | 磁気共鳴撮影システム |
| US7207989B2 (en) * | 2003-10-27 | 2007-04-24 | Biosense Webster, Inc. | Method for ablating with needle electrode |
| US20070208252A1 (en) * | 2004-04-21 | 2007-09-06 | Acclarent, Inc. | Systems and methods for performing image guided procedures within the ear, nose, throat and paranasal sinuses |
| JP2005339916A (ja) | 2004-05-26 | 2005-12-08 | Alps Electric Co Ltd | 接点基板及びエンコーダ |
| JP4528136B2 (ja) * | 2005-01-11 | 2010-08-18 | 株式会社日立製作所 | 手術装置 |
| US7930065B2 (en) * | 2005-12-30 | 2011-04-19 | Intuitive Surgical Operations, Inc. | Robotic surgery system including position sensors using fiber bragg gratings |
| JP2007187447A (ja) * | 2006-01-11 | 2007-07-26 | Ntn Corp | 内燃機関のシリンダ位置検出装置 |
| JP2008064208A (ja) * | 2006-09-07 | 2008-03-21 | Tokutake Seisakusho:Kk | ストローク検出機能付シリンダ装置 |
| US8684253B2 (en) * | 2007-01-10 | 2014-04-01 | Ethicon Endo-Surgery, Inc. | Surgical instrument with wireless communication between a control unit of a robotic system and remote sensor |
| JP5393952B2 (ja) * | 2007-03-01 | 2014-01-22 | 株式会社アイエイアイ | リニアエンコーダとアクチュエータ |
| US8050523B2 (en) | 2007-04-20 | 2011-11-01 | Koninklijke Philips Electronics N.V. | Optical fiber shape sensing systems |
| EP2193421B1 (en) * | 2007-09-20 | 2012-05-30 | Volvo Lastvagnar AB | Position detection arrangement and operating method for a position detection arrangement |
| US9179912B2 (en) * | 2008-02-14 | 2015-11-10 | Ethicon Endo-Surgery, Inc. | Robotically-controlled motorized surgical cutting and fastening instrument |
| US7815376B2 (en) | 2008-06-30 | 2010-10-19 | Intuitive Surgical Operations, Inc. | Fixture for shape-sensing optical fiber in a kinematic chain |
| US7720322B2 (en) * | 2008-06-30 | 2010-05-18 | Intuitive Surgical, Inc. | Fiber optic shape sensor |
| DE102008062624A1 (de) * | 2008-12-17 | 2010-06-24 | Kuka Roboter Gmbh | Handgerät und Verfahren zur Erfassung der Raumposition eines Arbeitspunktes eines Manipulators |
| JP5284837B2 (ja) * | 2009-03-23 | 2013-09-11 | オリンパス株式会社 | 光学式エンコーダ及び線状動力伝達部材の変位検出方法 |
| JP2010223723A (ja) * | 2009-03-23 | 2010-10-07 | Olympus Corp | 光学式エンコーダおよび操作装置 |
| US8305586B2 (en) | 2009-03-23 | 2012-11-06 | Olympus Corporation | Optical encoder, bending operation system, and method of detecting displacement of linear power transmission member |
| JP2011182845A (ja) | 2010-03-05 | 2011-09-22 | Hoya Corp | ズーム内視鏡 |
| US9782214B2 (en) * | 2010-11-05 | 2017-10-10 | Ethicon Llc | Surgical instrument with sensor and powered control |
| US8986303B2 (en) * | 2010-11-09 | 2015-03-24 | Biosense Webster, Inc. | Catheter with liquid-cooled control handle |
| JP5800616B2 (ja) * | 2011-07-15 | 2015-10-28 | オリンパス株式会社 | マニピュレータシステム |
| CN103717247B (zh) * | 2011-07-15 | 2016-04-27 | 赛诺菲-安万特德国有限公司 | 药物输送装置 |
| US10201365B2 (en) * | 2012-10-22 | 2019-02-12 | Ethicon Llc | Surgeon feedback sensing and display methods |
| WO2014098246A1 (en) * | 2012-12-20 | 2014-06-26 | Olympus Corporation | Position detection sensor and manipulator |
| JP6165080B2 (ja) * | 2014-02-21 | 2017-07-19 | オリンパス株式会社 | マニピュレータシステムの初期化方法 |
| JP6353665B2 (ja) * | 2014-02-21 | 2018-07-04 | オリンパス株式会社 | マニピュレータの初期化方法、マニピュレータ、およびマニピュレータシステム |
| US11273290B2 (en) * | 2014-09-10 | 2022-03-15 | Intuitive Surgical Operations, Inc. | Flexible instrument with nested conduits |
-
2013
- 2013-12-17 WO PCT/JP2013/084394 patent/WO2014098246A1/en not_active Ceased
- 2013-12-17 CN CN201380064290.XA patent/CN104838238B/zh active Active
- 2013-12-17 JP JP2015525331A patent/JP6033436B2/ja active Active
- 2013-12-17 EP EP13863726.9A patent/EP2936070A4/en not_active Withdrawn
-
2015
- 2015-06-16 US US14/740,465 patent/US9802324B2/en active Active
Also Published As
| Publication number | Publication date |
|---|---|
| US9802324B2 (en) | 2017-10-31 |
| JP2015537187A (ja) | 2015-12-24 |
| US20160001447A1 (en) | 2016-01-07 |
| EP2936070A1 (en) | 2015-10-28 |
| CN104838238B (zh) | 2017-03-08 |
| EP2936070A4 (en) | 2016-09-21 |
| CN104838238A (zh) | 2015-08-12 |
| WO2014098246A1 (en) | 2014-06-26 |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| JP2015537187A (ja) | 位置検出センサおよびマニピュレータ | |
| EP2979657B1 (en) | Medical instrument and medical system | |
| US10150220B2 (en) | Manipulator control method, manipulator, and manipulator system | |
| EP2052691B1 (en) | Medical device | |
| EP3170463A1 (en) | Instrument | |
| JP5985104B2 (ja) | 内視鏡装置 | |
| EP3040040A1 (en) | Gripping treatment device and gripping unit | |
| WO2015190514A1 (ja) | 内視鏡システム | |
| JP6188787B2 (ja) | マニピュレータ | |
| WO2007062179A2 (en) | Method of determining the shape of a bendable instrument | |
| CN114615918B (zh) | 外科设备的机械臂中的线缆和布线 | |
| JP6238844B2 (ja) | 手術用マニピュレータ操作装置および手術用マニピュレータシステム | |
| JP2015016181A (ja) | 手術支援ロボット | |
| EP3203924A2 (en) | Electromechanical surgical system | |
| WO2014021222A1 (ja) | 医療用マニピュレータ | |
| IL269091B1 (en) | A device for surgery with the help of electricity | |
| US20140031626A1 (en) | Endoscope | |
| CN106455914B (zh) | 引导装置和手术系统 | |
| WO2014007113A1 (ja) | 医療用マニピュレータ | |
| US12310557B2 (en) | Flexible tube insertion apparatus, control apparatus, and method of changing rigidity | |
| JP4406181B2 (ja) | 内視鏡装置 | |
| CN113164016A (zh) | 可挠管插入装置 | |
| EP3298947A1 (en) | Insertion device |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| A521 | Request for written amendment filed |
Free format text: JAPANESE INTERMEDIATE CODE: A821 Effective date: 20150518 |
|
| A621 | Written request for application examination |
Free format text: JAPANESE INTERMEDIATE CODE: A621 Effective date: 20150515 |
|
| A131 | Notification of reasons for refusal |
Free format text: JAPANESE INTERMEDIATE CODE: A131 Effective date: 20160315 |
|
| A521 | Request for written amendment filed |
Free format text: JAPANESE INTERMEDIATE CODE: A523 Effective date: 20160509 |
|
| A521 | Request for written amendment filed |
Free format text: JAPANESE INTERMEDIATE CODE: A821 Effective date: 20160510 |
|
| TRDD | Decision of grant or rejection written | ||
| A01 | Written decision to grant a patent or to grant a registration (utility model) |
Free format text: JAPANESE INTERMEDIATE CODE: A01 Effective date: 20161011 |
|
| A61 | First payment of annual fees (during grant procedure) |
Free format text: JAPANESE INTERMEDIATE CODE: A61 Effective date: 20161025 |
|
| R151 | Written notification of patent or utility model registration |
Ref document number: 6033436 Country of ref document: JP Free format text: JAPANESE INTERMEDIATE CODE: R151 |
|
| R250 | Receipt of annual fees |
Free format text: JAPANESE INTERMEDIATE CODE: R250 |
|
| R250 | Receipt of annual fees |
Free format text: JAPANESE INTERMEDIATE CODE: R250 |
|
| R250 | Receipt of annual fees |
Free format text: JAPANESE INTERMEDIATE CODE: R250 |
|
| R250 | Receipt of annual fees |
Free format text: JAPANESE INTERMEDIATE CODE: R250 |
|
| R250 | Receipt of annual fees |
Free format text: JAPANESE INTERMEDIATE CODE: R250 |
|
| R250 | Receipt of annual fees |
Free format text: JAPANESE INTERMEDIATE CODE: R250 |
|
| R250 | Receipt of annual fees |
Free format text: JAPANESE INTERMEDIATE CODE: R250 |