JP6892018B2 - ロボット装置 - Google Patents
ロボット装置 Download PDFInfo
- Publication number
- JP6892018B2 JP6892018B2 JP2020542217A JP2020542217A JP6892018B2 JP 6892018 B2 JP6892018 B2 JP 6892018B2 JP 2020542217 A JP2020542217 A JP 2020542217A JP 2020542217 A JP2020542217 A JP 2020542217A JP 6892018 B2 JP6892018 B2 JP 6892018B2
- Authority
- JP
- Japan
- Prior art keywords
- guide rail
- arm
- robot device
- elongated
- elongated strut
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Active
Links
Images






Classifications
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B25—HAND TOOLS; PORTABLE POWER-DRIVEN TOOLS; MANIPULATORS
- B25J—MANIPULATORS; CHAMBERS PROVIDED WITH MANIPULATION DEVICES
- B25J9/00—Program-controlled manipulators
- B25J9/02—Program-controlled manipulators characterised by movement of the arms, e.g. cartesian coordinate type
- B25J9/04—Program-controlled manipulators characterised by movement of the arms, e.g. cartesian coordinate type by rotating at least one arm, excluding the head movement itself, e.g. cylindrical coordinate type or polar coordinate type
- B25J9/041—Cylindrical coordinate type
- B25J9/042—Cylindrical coordinate type comprising an articulated arm
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B25—HAND TOOLS; PORTABLE POWER-DRIVEN TOOLS; MANIPULATORS
- B25J—MANIPULATORS; CHAMBERS PROVIDED WITH MANIPULATION DEVICES
- B25J18/00—Arms
- B25J18/02—Arms extensible
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B25—HAND TOOLS; PORTABLE POWER-DRIVEN TOOLS; MANIPULATORS
- B25J—MANIPULATORS; CHAMBERS PROVIDED WITH MANIPULATION DEVICES
- B25J5/00—Manipulators mounted on wheels or on carriages
- B25J5/02—Manipulators mounted on wheels or on carriages travelling along a guideway
- B25J5/04—Manipulators mounted on wheels or on carriages travelling along a guideway wherein the guideway is also moved, e.g. travelling crane bridge type
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B25—HAND TOOLS; PORTABLE POWER-DRIVEN TOOLS; MANIPULATORS
- B25J—MANIPULATORS; CHAMBERS PROVIDED WITH MANIPULATION DEVICES
- B25J9/00—Program-controlled manipulators
- B25J9/0009—Constructional details, e.g. manipulator supports, bases
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B25—HAND TOOLS; PORTABLE POWER-DRIVEN TOOLS; MANIPULATORS
- B25J—MANIPULATORS; CHAMBERS PROVIDED WITH MANIPULATION DEVICES
- B25J9/00—Program-controlled manipulators
- B25J9/02—Program-controlled manipulators characterised by movement of the arms, e.g. cartesian coordinate type
- B25J9/04—Program-controlled manipulators characterised by movement of the arms, e.g. cartesian coordinate type by rotating at least one arm, excluding the head movement itself, e.g. cylindrical coordinate type or polar coordinate type
- B25J9/041—Cylindrical coordinate type
- B25J9/042—Cylindrical coordinate type comprising an articulated arm
- B25J9/044—Cylindrical coordinate type comprising an articulated arm with forearm providing vertical linear movement
Landscapes
- Engineering & Computer Science (AREA)
- Robotics (AREA)
- Mechanical Engineering (AREA)
- Manipulator (AREA)
Description
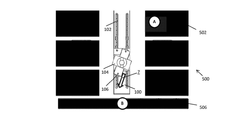
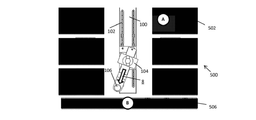
(a)2つの方向の移動を案内する、第1のガイドレールと、
(b)第2のガイドレールを含み、第1のガイドレールに沿って2つの方向に移動可能であり、且つ第1のガイドレールに沿った各位置で回転可能であるよう、第1のガイドレールに取り付けられた、細長い支柱と、
(c)第2のガイドレールに沿って移動可能となるよう、細長い支柱の第2のガイドレールに取り付けられた、伸長及び収縮可能な第1のアームと、
(d)第1アームの一端を中心に枢転可能となるよう、第1のアームの一端に枢転可能に取り付けられた、第2のアームと、
(e)第2のアームの一端で回転可能となるよう、第2のアームの一端に取り付けられた、エンドエフェクタマウントと、
(f)細長い支柱が第1のガイドレールに沿って移動可能な2つの方向に細長い支柱の移動を案内するため、細長い支柱に取り付けられ、細長い支柱がそれに沿った各位置で回転可能である、第3のガイドレールと、
(g)細長い支柱、第1のアーム、第2のアーム、エンドエフェクタマウントの動きを駆動するための、複数の駆動機構と
を含むロボット装置が提供される。
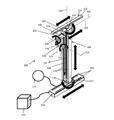
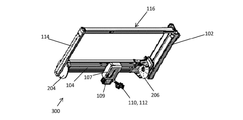
−第1のガイドレール102と第3のガイドレール114に沿った位置でロボット装置100に操作範囲を提供する、第1のガイドレール102とこれに対応する第3のガイドレール114;
−第1のアーム106の伸長及び収縮可能な特性;
−第1のアーム106が伸長した後に更に操作範囲を拡張する枢転可能な第2のアーム110;
−第2のガイドレール108に沿った位置でロボット装置100に操作範囲を提供する、第2のガイドレール108。
Claims (11)
- 2つの方向の移動を案内する、第1のガイドレールと、
前記第1のガイドレールに沿って前記2つの方向に移動可能であり、前記第1のガイドレールに沿った各位置で回転可能であるように、前記第1のガイドレールに取り付けられ、第2のガイドレールを含む、細長い支柱と、
前記第2のガイドレールに沿って移動可能であるよう、前記細長い支柱の前記第2のガイドレールに取り付けられた、伸長及び収縮可能な、第1のアームと、
前記第1のアームの一端で枢転可能であるよう、前記第1のアームの前記一端に枢転可能に取り付けられた、第2のアームと、
前記第2のアームの一端で回転可能であるよう、前記第2のアームの前記一端に位置する、エンドエフェクタマウントと、
前記細長い支柱が前記第1のガイドレールに沿って移動可能な前記2つの方向における前記細長い支柱の移動を案内するため、前記細長い支柱に取り付けられる第3のガイドレールであって、前記第3のガイドレールに沿った各位置で前記細長い支柱が回転可能である、第3のガイドレールと、
前記細長い支柱、前記第1のアーム、前記第2のアーム、前記エンドエフェクタマウントの動作を駆動するための、複数の駆動機構と
を含み、
前記第1のガイドレールが前記細長い支柱の一端に、前記第3のガイドレールが前記細長い支柱の他端に取り付けられる、
ロボット装置。 - 前記第1のガイドレールと前記第3のガイドレールとが、前記細長い支柱を通して互いに取り付けられた、
請求項1に記載のロボット装置。 - 前記第1のガイドレールに沿った前記位置での前記細長い支柱の前記回転が前記複数の駆動機構のうちの1つにより駆動され、前記第3のガイドレールに沿った前記位置での前記細長い支柱の前記回転が前記複数の駆動機構のうちの別の1つにより駆動される、
請求項1又は2に記載のロボット装置。 - 前記第1のガイドレールに沿った前記細長い支柱の前記移動が前記複数の駆動機構のうちの1つにより駆動され、前記第3のガイドレールに沿った前記細長い支柱の前記移動が前記複数の駆動機構のうちの別の1つにより駆動される、
請求項1〜3のいずれか1項に記載のロボット装置。 - 前記第1のガイドレールに沿った前記位置での前記細長い支柱の前記回転を駆動する前記駆動機構が、前記第3のガイドレールに沿った前記位置での前記細長い支柱の前記回転を駆動する前記駆動機構よりも強い駆動に構成された、
請求項3又は4に記載のロボット装置。 - 前記第1のガイドレールに沿った前記細長い支柱の前記移動を駆動する前記駆動機構が、前記第3のガイドレールに沿った前記細長い支柱の前記移動を駆動する前記駆動機構よりも強い駆動に構成された、
請求項3、4、又は5に記載のロボット装置。 - 長さ0.5m〜10m、幅0.1m〜1m、高さ0.5m〜3mの設置体積内に収まる大きさを有する、
請求項1から6のいずれか1項に記載のロボット装置。 - 前記エンドエフェクタマウントに取り付けられたエンドエフェクタが、前記ロボット装置の一部を中心に長さ1m、幅1m、高さ1mの作業空間内に届くことができる、
請求項1から7のいずれか1項に記載のロボット装置。 - 前記第2のアームの少なくとも1つの方向の枢転動作が前記細長い支柱により阻害されないよう、前記第1のアームが前記細長い支柱の前記第2のガイドレールに取り付けられた、
請求項1から8のいずれか1項に記載のロボット装置。 - 前記第1のアーム又は前記第2のアームの少なくとも一方が、伸長したとき、前記ロボット装置の一部を中心とした制限された作業空間を超えて伸長しないよう、前記細長い支柱が前記第1のガイドレールに沿った各位置で、ある角度に回転可能である、
請求項8に記載のロボット装置。 - 前記第1のアーム及び、前記エンドエフェクタマウントに載置されたエンドエフェクタの有無に関わらず前記エンドエフェクタマウントを含む前記第2のアームが、伸長したとき、前記ロボット装置の一部を中心とした制限された作業空間を超えて伸長しないよう、前記細長い支柱が前記第1のガイドレールに沿った各位置で、ある角度に回転可能である、
請求項8に記載のロボット装置。
Applications Claiming Priority (3)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| SG10201709233T | 2017-11-09 | ||
| SG10201709233T | 2017-11-09 | ||
| PCT/IB2018/058570 WO2019092557A1 (en) | 2017-11-09 | 2018-11-01 | A robotic apparatus |
Publications (3)
| Publication Number | Publication Date |
|---|---|
| JP2020536761A JP2020536761A (ja) | 2020-12-17 |
| JP2020536761A5 JP2020536761A5 (ja) | 2021-02-04 |
| JP6892018B2 true JP6892018B2 (ja) | 2021-06-18 |
Family
ID=66437722
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| JP2020542217A Active JP6892018B2 (ja) | 2017-11-09 | 2018-11-01 | ロボット装置 |
Country Status (5)
| Country | Link |
|---|---|
| US (1) | US11472023B2 (ja) |
| EP (1) | EP3706961B1 (ja) |
| JP (1) | JP6892018B2 (ja) |
| CN (1) | CN111183005B (ja) |
| WO (1) | WO2019092557A1 (ja) |
Families Citing this family (7)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| US10506730B2 (en) * | 2018-04-13 | 2019-12-10 | Aristocrat Technologies Australia Pty Limited | Overhead display assembly and method for electronic gaming machines |
| US11148289B1 (en) * | 2019-01-08 | 2021-10-19 | Amazon Technologies, Inc. | Entanglement end effector for autonomous object retrieval |
| CN111719356A (zh) * | 2020-06-10 | 2020-09-29 | 安徽博晟亿电力科技有限公司 | 一种铁路施工用辅助定位装置及方法 |
| CN114179056B (zh) * | 2021-12-13 | 2023-07-25 | 国网湖南省电力有限公司 | 一种gis室内多自由度挂轨式巡检机器人及其应用方法 |
| CN114750128B (zh) * | 2022-06-16 | 2022-09-09 | 中铁工程服务有限公司 | 机器人和管片拼装系统 |
| CN115026788A (zh) * | 2022-06-21 | 2022-09-09 | 中煤科工集团重庆研究院有限公司 | 一种煤矿机械手行走机构 |
| CN119550369B (zh) * | 2024-12-12 | 2025-10-24 | 广州智柔智能装备有限公司 | 一种末端执行器及机器人 |
Family Cites Families (24)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| US3262593A (en) | 1963-07-10 | 1966-07-26 | Gen Mills Inc | Wall-mounted support structure |
| DE1279907B (de) | 1965-11-30 | 1968-10-10 | Kernforschung Gmbh Ges Fuer | Ferngesteuerter Manipulator |
| US3834555A (en) * | 1972-12-04 | 1974-09-10 | Budd Co | Article transfer apparatus |
| SU603577A1 (ru) * | 1976-07-06 | 1978-04-25 | Ордена Ленина, Ордена Октябрьской Революции И Ордена Трудового Красного Знамени Завод "Ростсельмаш" | Промышленный робот |
| US4650952A (en) * | 1984-12-20 | 1987-03-17 | Gmf Robotics Corporation | Robot-laser system |
| AU3218189A (en) | 1988-05-31 | 1990-01-05 | Gordon T. Brown | Gantry robot construction |
| JPH06155353A (ja) * | 1992-11-10 | 1994-06-03 | Asake Seiko Kk | 部材の取出し供給装置 |
| JP2800669B2 (ja) * | 1993-12-24 | 1998-09-21 | 三菱電機株式会社 | 産業用ロボット |
| US5606262A (en) * | 1995-06-07 | 1997-02-25 | Teradyne, Inc. | Manipulator for automatic test equipment test head |
| SE9800984D0 (sv) * | 1998-03-24 | 1998-03-24 | Thordab Ab | Bearbetningsmaskin |
| JP4063781B2 (ja) * | 2004-03-04 | 2008-03-19 | 株式会社ラインワークス | 搬送装置 |
| DK1982799T3 (da) | 2007-04-10 | 2010-08-16 | Erowa Ag | Håndteringsapparat |
| US8973768B1 (en) | 2009-10-09 | 2015-03-10 | Par Systems, Inc. | Gantry robot system |
| CN102873682A (zh) * | 2011-07-15 | 2013-01-16 | 鸿富锦精密工业(深圳)有限公司 | 机械手及使用该机械手的生产设备及生产线 |
| KR101506188B1 (ko) | 2013-08-30 | 2015-03-26 | 주식회사 로보스타 | 멀티플 암을 구비한 반송 로봇 |
| US20150375390A1 (en) * | 2014-03-06 | 2015-12-31 | Encore Automation | Robotic system for applying surface finishes to large objects |
| JP6110810B2 (ja) * | 2014-04-22 | 2017-04-05 | 株式会社ラインワークス | 溶接装置 |
| CN204094784U (zh) | 2014-06-10 | 2015-01-14 | 温州职业技术学院 | 伺服控制的四自由度机械手 |
| US10137566B2 (en) * | 2015-09-09 | 2018-11-27 | Bastian Solutions, Llc | Automated guided vehicle (AGV) with batch picking robotic arm |
| WO2017136429A1 (en) * | 2016-02-01 | 2017-08-10 | AM Networks LLC | Desktop robotic arm with interchangeable end effectors |
| HUP1600186A2 (en) * | 2016-03-08 | 2017-09-28 | Cnc-Instruments Bt | Device and method for constructing buildings by 3d printing |
| CN106426120B (zh) | 2016-11-22 | 2019-03-22 | 大连交通大学 | 一种重负荷龙门式机器人 |
| CN107243898B (zh) | 2017-06-09 | 2024-01-30 | 陕西科技大学 | 一种连杆式智能机器人 |
| US10828770B2 (en) * | 2017-08-24 | 2020-11-10 | GM Global Technology Operations LLC | Power delivery system for electric vehicle charging station |
-
2018
- 2018-11-01 WO PCT/IB2018/058570 patent/WO2019092557A1/en not_active Ceased
- 2018-11-01 CN CN201880064858.0A patent/CN111183005B/zh active Active
- 2018-11-01 US US16/754,141 patent/US11472023B2/en active Active
- 2018-11-01 EP EP18875850.2A patent/EP3706961B1/en active Active
- 2018-11-01 JP JP2020542217A patent/JP6892018B2/ja active Active
Also Published As
| Publication number | Publication date |
|---|---|
| EP3706961B1 (en) | 2023-03-08 |
| JP2020536761A (ja) | 2020-12-17 |
| US11472023B2 (en) | 2022-10-18 |
| EP3706961A1 (en) | 2020-09-16 |
| CN111183005A (zh) | 2020-05-19 |
| EP3706961A4 (en) | 2021-09-08 |
| CN111183005B (zh) | 2023-06-23 |
| WO2019092557A1 (en) | 2019-05-16 |
| US20200331142A1 (en) | 2020-10-22 |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| JP2020536761A5 (ja) | ||
| JP2020536761A (ja) | ロボット装置 | |
| US9156160B2 (en) | Robot system, calibration method, and method for producing to-be-processed material | |
| JP6173677B2 (ja) | 産業用ロボットの原点位置復帰方法 | |
| CN107215404B (zh) | 机器人、机器人系统及相关的方法 | |
| CN117355392A (zh) | 集成移动机械手机器人 | |
| JP6252597B2 (ja) | ロボットシステム | |
| US20190054637A1 (en) | Extending robotic arm | |
| CN107949459B (zh) | 采用连杆操作装置的复合作业装置 | |
| JPWO2017037976A1 (ja) | 基板移載装置 | |
| JP6875348B2 (ja) | ロボットおよび第1アーム部材 | |
| JP2008506545A (ja) | 2つのサブアセンブリ手段から構成される可動要素を移動させる手段を備えるパラレルロボット | |
| CN108789482A (zh) | 机器人 | |
| TW201617192A (zh) | 機器人及機器人系統 | |
| EP2737980A1 (en) | Robot disposed adjacent to a conveyance path and retractable in a parking position | |
| CN110545952A (zh) | 机器人系统和具备该机器人系统的工作线 | |
| Shikari et al. | Triple scissor extender robot arm: a solution to the last one foot problem of manipulation | |
| JP2024511791A (ja) | 非接触式の搬送装置 | |
| Borkar et al. | Advancing pharmaceutical manufacturing through Delta robot fabrication | |
| US12338081B2 (en) | Conveying device and robot system | |
| Seo et al. | A new planar 3-DOF parallel mechanism with continuous 360-degree rotational capability | |
| Yu et al. | Conceptual design and workspace analysis of reconfigurable fixturing robots for sheet metal assembly | |
| Paatz | Anatomy of a Robot | |
| CN206425693U (zh) | 四轴联动平台 | |
| JP2001001291A (ja) | ロボットの動作制御装置 |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| A521 | Request for written amendment filed |
Free format text: JAPANESE INTERMEDIATE CODE: A523 Effective date: 20200415 |
|
| A621 | Written request for application examination |
Free format text: JAPANESE INTERMEDIATE CODE: A621 Effective date: 20200415 |
|
| A131 | Notification of reasons for refusal |
Free format text: JAPANESE INTERMEDIATE CODE: A131 Effective date: 20210216 |
|
| A521 | Request for written amendment filed |
Free format text: JAPANESE INTERMEDIATE CODE: A523 Effective date: 20210414 |
|
| TRDD | Decision of grant or rejection written | ||
| A01 | Written decision to grant a patent or to grant a registration (utility model) |
Free format text: JAPANESE INTERMEDIATE CODE: A01 Effective date: 20210427 |
|
| A61 | First payment of annual fees (during grant procedure) |
Free format text: JAPANESE INTERMEDIATE CODE: A61 Effective date: 20210510 |
|
| R150 | Certificate of patent or registration of utility model |
Ref document number: 6892018 Country of ref document: JP Free format text: JAPANESE INTERMEDIATE CODE: R150 |
|
| R250 | Receipt of annual fees |
Free format text: JAPANESE INTERMEDIATE CODE: R250 |