KR20170024231A - 경사로에서의 차량 브레이크 제어 방법 - Google Patents
경사로에서의 차량 브레이크 제어 방법 Download PDFInfo
- Publication number
- KR20170024231A KR20170024231A KR1020150119101A KR20150119101A KR20170024231A KR 20170024231 A KR20170024231 A KR 20170024231A KR 1020150119101 A KR1020150119101 A KR 1020150119101A KR 20150119101 A KR20150119101 A KR 20150119101A KR 20170024231 A KR20170024231 A KR 20170024231A
- Authority
- KR
- South Korea
- Prior art keywords
- vehicle
- torque value
- motor torque
- ramp
- brake
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Ceased
Links
- 238000000034 method Methods 0.000 title abstract description 28
- 230000001133 acceleration Effects 0.000 claims description 12
- 230000010355 oscillation Effects 0.000 description 4
- 230000005540 biological transmission Effects 0.000 description 3
- 230000009191 jumping Effects 0.000 description 2
- 239000000470 constituent Substances 0.000 description 1
- 230000000994 depressogenic effect Effects 0.000 description 1
- 239000000446 fuel Substances 0.000 description 1
- 239000007788 liquid Substances 0.000 description 1
Images


Classifications
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B60—VEHICLES IN GENERAL
- B60W—CONJOINT CONTROL OF VEHICLE SUB-UNITS OF DIFFERENT TYPE OR DIFFERENT FUNCTION; CONTROL SYSTEMS SPECIALLY ADAPTED FOR HYBRID VEHICLES; ROAD VEHICLE DRIVE CONTROL SYSTEMS FOR PURPOSES NOT RELATED TO THE CONTROL OF A PARTICULAR SUB-UNIT
- B60W30/00—Purposes of road vehicle drive control systems not related to the control of a particular sub-unit, e.g. of systems using conjoint control of vehicle sub-units
- B60W30/18—Propelling the vehicle
- B60W30/18009—Propelling the vehicle related to particular drive situations
- B60W30/18027—Drive off, accelerating from standstill
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B60—VEHICLES IN GENERAL
- B60W—CONJOINT CONTROL OF VEHICLE SUB-UNITS OF DIFFERENT TYPE OR DIFFERENT FUNCTION; CONTROL SYSTEMS SPECIALLY ADAPTED FOR HYBRID VEHICLES; ROAD VEHICLE DRIVE CONTROL SYSTEMS FOR PURPOSES NOT RELATED TO THE CONTROL OF A PARTICULAR SUB-UNIT
- B60W10/00—Conjoint control of vehicle sub-units of different type or different function
- B60W10/18—Conjoint control of vehicle sub-units of different type or different function including control of braking systems
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B60—VEHICLES IN GENERAL
- B60W—CONJOINT CONTROL OF VEHICLE SUB-UNITS OF DIFFERENT TYPE OR DIFFERENT FUNCTION; CONTROL SYSTEMS SPECIALLY ADAPTED FOR HYBRID VEHICLES; ROAD VEHICLE DRIVE CONTROL SYSTEMS FOR PURPOSES NOT RELATED TO THE CONTROL OF A PARTICULAR SUB-UNIT
- B60W40/00—Estimation or calculation of non-directly measurable driving parameters for road vehicle drive control systems not related to the control of a particular sub unit, e.g. by using mathematical models
- B60W40/02—Estimation or calculation of non-directly measurable driving parameters for road vehicle drive control systems not related to the control of a particular sub unit, e.g. by using mathematical models related to ambient conditions
- B60W40/06—Road conditions
- B60W40/076—Slope angle of the road
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B60—VEHICLES IN GENERAL
- B60W—CONJOINT CONTROL OF VEHICLE SUB-UNITS OF DIFFERENT TYPE OR DIFFERENT FUNCTION; CONTROL SYSTEMS SPECIALLY ADAPTED FOR HYBRID VEHICLES; ROAD VEHICLE DRIVE CONTROL SYSTEMS FOR PURPOSES NOT RELATED TO THE CONTROL OF A PARTICULAR SUB-UNIT
- B60W40/00—Estimation or calculation of non-directly measurable driving parameters for road vehicle drive control systems not related to the control of a particular sub unit, e.g. by using mathematical models
- B60W40/10—Estimation or calculation of non-directly measurable driving parameters for road vehicle drive control systems not related to the control of a particular sub unit, e.g. by using mathematical models related to vehicle motion
- B60W40/105—Speed
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B60—VEHICLES IN GENERAL
- B60W—CONJOINT CONTROL OF VEHICLE SUB-UNITS OF DIFFERENT TYPE OR DIFFERENT FUNCTION; CONTROL SYSTEMS SPECIALLY ADAPTED FOR HYBRID VEHICLES; ROAD VEHICLE DRIVE CONTROL SYSTEMS FOR PURPOSES NOT RELATED TO THE CONTROL OF A PARTICULAR SUB-UNIT
- B60W2420/00—Indexing codes relating to the type of sensors based on the principle of their operation
- B60W2420/50—Magnetic or electromagnetic sensors
- B60W2420/503—Hall effect or magnetoresistive, i.e. active wheel speed sensors
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B60—VEHICLES IN GENERAL
- B60W—CONJOINT CONTROL OF VEHICLE SUB-UNITS OF DIFFERENT TYPE OR DIFFERENT FUNCTION; CONTROL SYSTEMS SPECIALLY ADAPTED FOR HYBRID VEHICLES; ROAD VEHICLE DRIVE CONTROL SYSTEMS FOR PURPOSES NOT RELATED TO THE CONTROL OF A PARTICULAR SUB-UNIT
- B60W2510/00—Input parameters relating to a particular sub-units
- B60W2510/08—Electric propulsion units
- B60W2510/083—Torque
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B60—VEHICLES IN GENERAL
- B60W—CONJOINT CONTROL OF VEHICLE SUB-UNITS OF DIFFERENT TYPE OR DIFFERENT FUNCTION; CONTROL SYSTEMS SPECIALLY ADAPTED FOR HYBRID VEHICLES; ROAD VEHICLE DRIVE CONTROL SYSTEMS FOR PURPOSES NOT RELATED TO THE CONTROL OF A PARTICULAR SUB-UNIT
- B60W2710/00—Output or target parameters relating to a particular sub-units
- B60W2710/09—Other types of propulsion units, e.g. fluid motors, or type not specified
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B60—VEHICLES IN GENERAL
- B60Y—INDEXING SCHEME RELATING TO ASPECTS CROSS-CUTTING VEHICLE TECHNOLOGY
- B60Y2200/00—Type of vehicle
- B60Y2200/90—Vehicles comprising electric prime movers
- B60Y2200/91—Electric vehicles
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B60—VEHICLES IN GENERAL
- B60Y—INDEXING SCHEME RELATING TO ASPECTS CROSS-CUTTING VEHICLE TECHNOLOGY
- B60Y2200/00—Type of vehicle
- B60Y2200/90—Vehicles comprising electric prime movers
- B60Y2200/92—Hybrid vehicles
Landscapes
- Engineering & Computer Science (AREA)
- Transportation (AREA)
- Mechanical Engineering (AREA)
- Automation & Control Theory (AREA)
- Physics & Mathematics (AREA)
- Mathematical Physics (AREA)
- Chemical & Material Sciences (AREA)
- Combustion & Propulsion (AREA)
- Electric Propulsion And Braking For Vehicles (AREA)
Abstract
Description

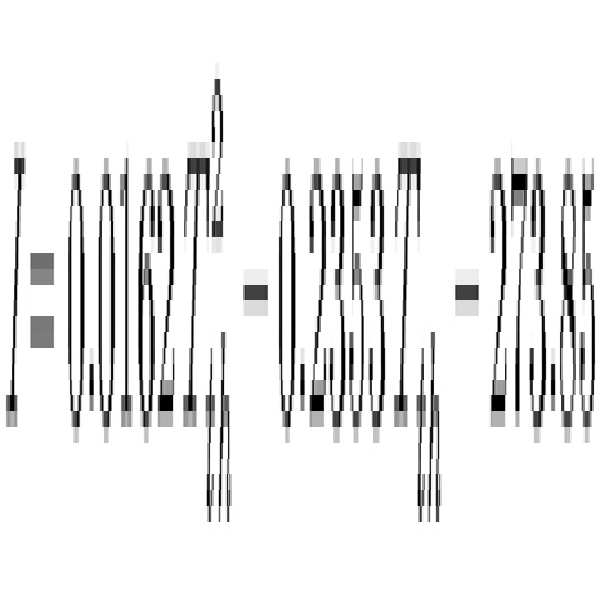
도 2는 본 발명에 따른 경사로에서의 차량 브레이크 제어 방법에서 전류값과 차량의 모터 토크값과의 관계에 따른 실험값을 표로 도시한 도,
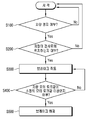
도 3은 본 발명에 따른 경사로에서의 차량 브레이크 제어 방법을 설명하기 위한 순서도이다.
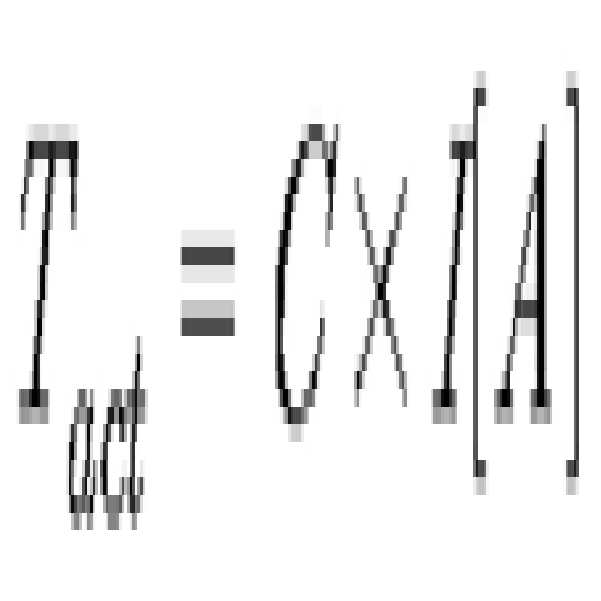

200: 전류 센서
300: 홀 센서
400: 가속도 센서
500: 브레이크 시스템
Claims (7)
- (a) 차량의 차속이 센싱되는 단계;
(b) 상기 차량의 기울기가 센싱되는 단계;
(c) 상기 차량이 상기 차량의 기울기를 갖는 경사로에서 발진하는데 필요한 소정의 모터 토크값이 연산되는 단계;
(d) 상기 차량의 모터 토크값이 센싱되는 단계; 및
(e) 상기 차량의 모터 토크값이 상기 소정의 모터 토크값 이상인 때에 상기 차량의 브레이크가 해제되는 단계를 포함하는 차량 브레이크 제어 방법.
- 청구항 1에서,
상기 (a) 단계에서 상기 차량의 차속이 0km/h인 때에 상기 (b) 단계가 진행되며, 그리고
(b1) 상기 (b) 단계 이후, 상기 차량의 기울기가 0보다 큰 때에 상기 차량의 브레이크가 작동되는 단계를 더 포함하는 차량 브레이크 제어 방법.
- 청구항 2에서,
상기 차량의 모터 토크값은 전류센서(200)에 의해 센싱되는 차량 브레이크 제어 방법.
- 청구항 3에서,
상기 차량의 모터 토크값은 하기의 식에 의하여 연산되는 차량 브레이크 제어 방법.

여기에서,
I는 전류값이며, 그리고
Tth는 차량의 모터 토크값임
- 청구항 4에서,
상기 차량의 차속은 홀센서(300)에 의해 센싱되며,
상기 차량의 기울기는 가속도 센서(400)에 의해 센싱되며,
상기 차량의 기울기 값은 MCU(100)에 전송되며, 그리고
상기 소정의 모터 토크값은 상기 MCU(100)에서 연산되는 차량 브레이크 제어 방법.
- 청구항 5에서,
상기 차량은 하이브리드차 또는 전기차인 차량 브레이크 제어 방법.
- 청구항 3에서,
상기 차량의 모터 토크값과 전류값은 테일러 급수에 의해 연산되는 차량 브레이크 제어 방법.
Priority Applications (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| KR1020150119101A KR20170024231A (ko) | 2015-08-24 | 2015-08-24 | 경사로에서의 차량 브레이크 제어 방법 |
Applications Claiming Priority (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| KR1020150119101A KR20170024231A (ko) | 2015-08-24 | 2015-08-24 | 경사로에서의 차량 브레이크 제어 방법 |
Publications (1)
| Publication Number | Publication Date |
|---|---|
| KR20170024231A true KR20170024231A (ko) | 2017-03-07 |
Family
ID=58411547
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| KR1020150119101A Ceased KR20170024231A (ko) | 2015-08-24 | 2015-08-24 | 경사로에서의 차량 브레이크 제어 방법 |
Country Status (1)
| Country | Link |
|---|---|
| KR (1) | KR20170024231A (ko) |
Cited By (2)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| KR20200057846A (ko) * | 2018-11-15 | 2020-05-27 | 현대자동차주식회사 | 차량의 언덕길 밀림방지 제어방법과 시스템 및 언덕길 밀림방지 시스템을 포함하는 차량 |
| CN111409640A (zh) * | 2020-03-05 | 2020-07-14 | 吉利汽车研究院(宁波)有限公司 | 坡道起步防溜坡控制方法、装置、设备及存储介质 |
-
2015
- 2015-08-24 KR KR1020150119101A patent/KR20170024231A/ko not_active Ceased
Cited By (2)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| KR20200057846A (ko) * | 2018-11-15 | 2020-05-27 | 현대자동차주식회사 | 차량의 언덕길 밀림방지 제어방법과 시스템 및 언덕길 밀림방지 시스템을 포함하는 차량 |
| CN111409640A (zh) * | 2020-03-05 | 2020-07-14 | 吉利汽车研究院(宁波)有限公司 | 坡道起步防溜坡控制方法、装置、设备及存储介质 |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| CN113260529B (zh) | 用于提供单踏板感觉和/或爬行功能的控制单元 | |
| CN107949512B (zh) | 用于控制车辆速度的方法和系统 | |
| EP3107789B1 (en) | Vehicle movement on an inclined surface | |
| JP5936817B2 (ja) | 自動車用坂道発進補助方法、坂道発進補助装置及び車両 | |
| CN106553632B (zh) | 一种控制车辆从静止起步的方法 | |
| JP6726272B2 (ja) | 車速制御方法及び車速制御システム | |
| CN106427600A (zh) | 一种用于电驱动汽车的下坡辅助驾驶装置及控制方法 | |
| EP1581418B1 (en) | Method and device for hill start | |
| GB2389090A (en) | Auxiliary drive system opposing downhill motion | |
| KR101294163B1 (ko) | 하이브리드 전기차량의 언덕길 밀림방지 제어방법 | |
| CN110182190B (zh) | 用于驻车制动释放的方法、装置和控制单元 | |
| WO2008081619A1 (ja) | 車両の制御装置、制御方法、およびその方法を実現するプログラムを記録した記録媒体 | |
| JP5583323B2 (ja) | 原動機を備えた車両のブレーキ装置作動方法 | |
| CN105517861A (zh) | 坡道倒溜速度控制 | |
| US10894540B2 (en) | Vehicle control apparatus | |
| CN100460253C (zh) | 限制汽车回退的方法和装置 | |
| JP4163844B2 (ja) | 車両の追突回避装置 | |
| CN103930325B (zh) | 用于控制机动车辆在斜坡上的速度的功能 | |
| KR20120052272A (ko) | 자동차의 크리핑 과정 제어 방법 | |
| KR20160148208A (ko) | 전자식 주차 브레이크 시스템 | |
| CN107107902A (zh) | 将机动车自动切换到惯性滑行模式的方法 | |
| JP2017065539A (ja) | 車両用停車制御装置 | |
| US11279330B2 (en) | Braking force control apparatus for a vehicle | |
| JP6063222B2 (ja) | 車両の走行制御装置 | |
| KR102224160B1 (ko) | 하이브리드 차량의 경사로 밀림 방지 제어 장치 |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| A201 | Request for examination | ||
| PA0109 | Patent application |
Patent event code: PA01091R01D Comment text: Patent Application Patent event date: 20150824 |
|
| PA0201 | Request for examination | ||
| E902 | Notification of reason for refusal | ||
| PE0902 | Notice of grounds for rejection |
Comment text: Notification of reason for refusal Patent event date: 20160906 Patent event code: PE09021S01D |
|
| E601 | Decision to refuse application | ||
| PE0601 | Decision on rejection of patent |
Patent event date: 20170222 Comment text: Decision to Refuse Application Patent event code: PE06012S01D Patent event date: 20160906 Comment text: Notification of reason for refusal Patent event code: PE06011S01I |
|
| PG1501 | Laying open of application |