KR20170143397A - 라인레이저가 장착된 엔드이펙터 - Google Patents
라인레이저가 장착된 엔드이펙터 Download PDFInfo
- Publication number
- KR20170143397A KR20170143397A KR1020160077615A KR20160077615A KR20170143397A KR 20170143397 A KR20170143397 A KR 20170143397A KR 1020160077615 A KR1020160077615 A KR 1020160077615A KR 20160077615 A KR20160077615 A KR 20160077615A KR 20170143397 A KR20170143397 A KR 20170143397A
- Authority
- KR
- South Korea
- Prior art keywords
- line laser
- needle
- guide
- main body
- support portion
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Granted
Links
Images


Classifications
-
- A—HUMAN NECESSITIES
- A61—MEDICAL OR VETERINARY SCIENCE; HYGIENE
- A61B—DIAGNOSIS; SURGERY; IDENTIFICATION
- A61B90/00—Instruments, implements or accessories specially adapted for surgery or diagnosis and not covered by any of the groups A61B1/00 - A61B50/00, e.g. for luxation treatment or for protecting wound edges
- A61B90/39—Markers, e.g. radio-opaque or breast lesions markers
-
- A—HUMAN NECESSITIES
- A61—MEDICAL OR VETERINARY SCIENCE; HYGIENE
- A61B—DIAGNOSIS; SURGERY; IDENTIFICATION
- A61B90/00—Instruments, implements or accessories specially adapted for surgery or diagnosis and not covered by any of the groups A61B1/00 - A61B50/00, e.g. for luxation treatment or for protecting wound edges
- A61B90/10—Instruments, implements or accessories specially adapted for surgery or diagnosis and not covered by any of the groups A61B1/00 - A61B50/00, e.g. for luxation treatment or for protecting wound edges for stereotaxic surgery, e.g. frame-based stereotaxis
- A61B90/11—Instruments, implements or accessories specially adapted for surgery or diagnosis and not covered by any of the groups A61B1/00 - A61B50/00, e.g. for luxation treatment or for protecting wound edges for stereotaxic surgery, e.g. frame-based stereotaxis with guides for needles or instruments, e.g. arcuate slides or ball joints
- A61B90/13—Instruments, implements or accessories specially adapted for surgery or diagnosis and not covered by any of the groups A61B1/00 - A61B50/00, e.g. for luxation treatment or for protecting wound edges for stereotaxic surgery, e.g. frame-based stereotaxis with guides for needles or instruments, e.g. arcuate slides or ball joints guided by light, e.g. laser pointers
-
- A—HUMAN NECESSITIES
- A61—MEDICAL OR VETERINARY SCIENCE; HYGIENE
- A61B—DIAGNOSIS; SURGERY; IDENTIFICATION
- A61B10/00—Instruments for taking body samples for diagnostic purposes; Other methods or instruments for diagnosis, e.g. for vaccination diagnosis, sex determination or ovulation-period determination; Throat striking implements
- A61B10/02—Instruments for taking cell samples or for biopsy
-
- A—HUMAN NECESSITIES
- A61—MEDICAL OR VETERINARY SCIENCE; HYGIENE
- A61B—DIAGNOSIS; SURGERY; IDENTIFICATION
- A61B10/00—Instruments for taking body samples for diagnostic purposes; Other methods or instruments for diagnosis, e.g. for vaccination diagnosis, sex determination or ovulation-period determination; Throat striking implements
- A61B10/02—Instruments for taking cell samples or for biopsy
- A61B10/0233—Pointed or sharp biopsy instruments
-
- A—HUMAN NECESSITIES
- A61—MEDICAL OR VETERINARY SCIENCE; HYGIENE
- A61B—DIAGNOSIS; SURGERY; IDENTIFICATION
- A61B17/00—Surgical instruments, devices or methods
- A61B17/34—Trocars; Puncturing needles
- A61B17/3403—Needle locating or guiding means
-
- A—HUMAN NECESSITIES
- A61—MEDICAL OR VETERINARY SCIENCE; HYGIENE
- A61B—DIAGNOSIS; SURGERY; IDENTIFICATION
- A61B6/00—Apparatus or devices for radiation diagnosis; Apparatus or devices for radiation diagnosis combined with radiation therapy equipment
- A61B6/02—Arrangements for diagnosis sequentially in different planes; Stereoscopic radiation diagnosis
- A61B6/03—Computed tomography [CT]
-
- A—HUMAN NECESSITIES
- A61—MEDICAL OR VETERINARY SCIENCE; HYGIENE
- A61B—DIAGNOSIS; SURGERY; IDENTIFICATION
- A61B6/00—Apparatus or devices for radiation diagnosis; Apparatus or devices for radiation diagnosis combined with radiation therapy equipment
- A61B6/02—Arrangements for diagnosis sequentially in different planes; Stereoscopic radiation diagnosis
- A61B6/03—Computed tomography [CT]
- A61B6/032—Transmission computed tomography [CT]
-
- A—HUMAN NECESSITIES
- A61—MEDICAL OR VETERINARY SCIENCE; HYGIENE
- A61B—DIAGNOSIS; SURGERY; IDENTIFICATION
- A61B90/00—Instruments, implements or accessories specially adapted for surgery or diagnosis and not covered by any of the groups A61B1/00 - A61B50/00, e.g. for luxation treatment or for protecting wound edges
- A61B90/36—Image-producing devices or illumination devices not otherwise provided for
- A61B90/37—Surgical systems with images on a monitor during operation
-
- A—HUMAN NECESSITIES
- A61—MEDICAL OR VETERINARY SCIENCE; HYGIENE
- A61B—DIAGNOSIS; SURGERY; IDENTIFICATION
- A61B17/00—Surgical instruments, devices or methods
- A61B17/34—Trocars; Puncturing needles
- A61B17/3403—Needle locating or guiding means
- A61B2017/3405—Needle locating or guiding means using mechanical guide means
- A61B2017/3409—Needle locating or guiding means using mechanical guide means including needle or instrument drives
-
- A—HUMAN NECESSITIES
- A61—MEDICAL OR VETERINARY SCIENCE; HYGIENE
- A61B—DIAGNOSIS; SURGERY; IDENTIFICATION
- A61B90/00—Instruments, implements or accessories specially adapted for surgery or diagnosis and not covered by any of the groups A61B1/00 - A61B50/00, e.g. for luxation treatment or for protecting wound edges
- A61B90/36—Image-producing devices or illumination devices not otherwise provided for
- A61B90/37—Surgical systems with images on a monitor during operation
- A61B2090/376—Surgical systems with images on a monitor during operation using X-rays, e.g. fluoroscopy
- A61B2090/3762—Surgical systems with images on a monitor during operation using X-rays, e.g. fluoroscopy using computed tomography systems [CT]
-
- A—HUMAN NECESSITIES
- A61—MEDICAL OR VETERINARY SCIENCE; HYGIENE
- A61B—DIAGNOSIS; SURGERY; IDENTIFICATION
- A61B90/00—Instruments, implements or accessories specially adapted for surgery or diagnosis and not covered by any of the groups A61B1/00 - A61B50/00, e.g. for luxation treatment or for protecting wound edges
- A61B90/39—Markers, e.g. radio-opaque or breast lesions markers
- A61B2090/3937—Visible markers
-
- A—HUMAN NECESSITIES
- A61—MEDICAL OR VETERINARY SCIENCE; HYGIENE
- A61B—DIAGNOSIS; SURGERY; IDENTIFICATION
- A61B90/00—Instruments, implements or accessories specially adapted for surgery or diagnosis and not covered by any of the groups A61B1/00 - A61B50/00, e.g. for luxation treatment or for protecting wound edges
- A61B90/39—Markers, e.g. radio-opaque or breast lesions markers
- A61B2090/3983—Reference marker arrangements for use with image guided surgery
Landscapes
- Health & Medical Sciences (AREA)
- Life Sciences & Earth Sciences (AREA)
- Engineering & Computer Science (AREA)
- Surgery (AREA)
- Medical Informatics (AREA)
- General Health & Medical Sciences (AREA)
- Animal Behavior & Ethology (AREA)
- Public Health (AREA)
- Pathology (AREA)
- Veterinary Medicine (AREA)
- Biomedical Technology (AREA)
- Heart & Thoracic Surgery (AREA)
- Molecular Biology (AREA)
- Nuclear Medicine, Radiotherapy & Molecular Imaging (AREA)
- Physics & Mathematics (AREA)
- Optics & Photonics (AREA)
- Radiology & Medical Imaging (AREA)
- Oral & Maxillofacial Surgery (AREA)
- High Energy & Nuclear Physics (AREA)
- Biophysics (AREA)
- Theoretical Computer Science (AREA)
- Pulmonology (AREA)
- Gynecology & Obstetrics (AREA)
- Surgical Instruments (AREA)
- Apparatus For Radiation Diagnosis (AREA)
- Laser Surgery Devices (AREA)
Abstract
Description
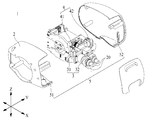
도 2는 본 발명에 따른 라인레이저가 장착된 엔드이펙터의 개략적인 분해사시도
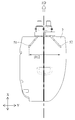
도 3은 본 발명에 따른 라인레이저가 장착된 엔드이펙터에서 라인레이저부를 설명하기 위한 개략적인 평면도
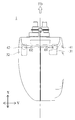
도 4는 본 발명에 따른 라인레이저가 장착된 엔드이펙터에서 가이드부를 설명하기 위한 개략적인 저면도
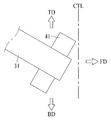
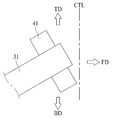
도 5 내지 도 7은 본 발명에 따른 라인레이저가 장착된 엔드이펙터가 일정 각도 내에서 기울어져도 라인레이저부가 컴퓨터 단층촬영에 간섭되지 않는 것을 설명하기 위한 개략적인 작동상태도
도 8은 본 발명에 따른 라인레이저가 장착된 엔드이펙터가 바늘삽입점을 표시하는 것을 설명하기 위한 개략적인 정면도
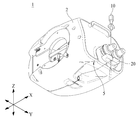
2 : 본체 3 : 지지부
4 : 라인레이저부 41 : 제1라인레이저기구
42 : 제2라인레이저기구 5 : 가이드부
51 : 제1가이드공 52 : 제2가이드공
Claims (7)
- 엔드이펙터의 몸체를 형성하는 본체;
상기 본체의 내부에 설치되고 바늘을 가이드하기 위한 바늘가이드기구를 지지하는 지지부;
상기 지지부의 일측 및 타측에 설치되고 환자의 환부에 바늘이 삽입되는 바늘삽입점을 표시하기 위해 라인레이저빔을 조사하는 라인레이저부; 및
상기 라인레이저부로부터 조사되는 라인레이저빔을 교차시키기 위해 상기 라인레이저빔을 가이드하는 가이드부를 포함하고,
상기 라인레이저부는 상기 바늘가이드기구로부터 기설정된 이격거리에 상기 바늘삽입점이 표시되도록 상기 가이드부를 통해 라인레이저빔을 조사하는 것을 특징으로 하는 라인레이저가 장착된 엔드이펙터. - 제1항에 있어서,
상기 라인레이저부는 상기 지지부의 일측에 설치되는 제1라인레이저기구 및 상기 지지부의 타측에 설치되는 제2라인레이저기구를 포함하고,
상기 가이드부는 상기 본체를 관통하여 형성되고, 상기 제1라인레이저기구가 조사하는 라인레이저빔이 통과하는 제1가이드공 및 상기 제1가이드공과 이격된 위치에 형성되고 상기 제2라인레이저기구가 조사하는 라인레이저빔이 통과하는 제2가이드공을 포함하며,
상기 제1가이드공 및 상기 제2가이드공은 상기 제1라인레이저기구 및 상기 제2라인레이저기구가 각각 조사하는 라인레이저빔이 교차되도록 상기 지지부에서 상기 바늘가이드기구를 향하는 전진방향으로 갈수록 이격된 이격거리가 감소되게 상기 본체에 형성되는 것을 특징으로 하는 라인레이저가 장착된 엔드이펙터. - 제2항에 있어서,
상기 제1라인레이저기구 및 상기 제2라인레이저기구는 상기 바늘가이드기구를 기준으로 대칭되도록 상기 지지부에 결합되는 것을 특징으로 하는 라인레이저가 장착된 엔드이펙터. - 제2항에 있어서,
상기 제1라인레이저기구는 상기 지지부의 일측에서 상기 지지부의 타측을 향하는 제1방향으로 이동 가능하게 상기 지지부에 결합되고,
상기 제2라인레이저기구는 상기 제1방향과 반대되는 제2방향으로 이동 가능하게 상기 지지부에 결합되는 것을 특징으로 하는 라인레이저가 장착된 엔드이펙터. - 제2항에 있어서,
상기 제1라인레이저기구 및 상기 제2라인레이저기구는 상기 전진방향 및 라인레이저빔이 조사되는 하측방향과 반대되는 상측방향 중 적어도 한 곳으로 이동 가능하게 상기 지지부에 결합되는 것을 특징으로 하는 라인레이저가 장착된 엔드이펙터. - 제1항에 있어서,
상기 라인레이저부는 영상장비인 CT(Computerized Tomography)가 상기 엔드이펙터의 상측에서 하측방향으로 바늘의 끝단을 촬영하는데 간섭되지 않도록 상기 지지부에 설치되는 것을 특징으로 하는 라인레이저가 장착된 엔드이펙터. - 제2항에 있어서,
상기 바늘삽입점은 상기 제1라인레이저기구 및 상기 제2라인레이저기구가 각각 조사하는 라인레인저빔이 상기 바늘가이드기구의 하측에서 최초로 교차되는 최초 교차점인 것을 특징으로 하는 라인레이저가 장착된 엔드이펙터.
Priority Applications (7)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| KR1020160077615A KR102530305B1 (ko) | 2016-06-21 | 2016-06-21 | 라인레이저가 장착된 엔드이펙터 |
| DK17815687.3T DK3473203T3 (da) | 2016-06-21 | 2017-06-20 | Endeeffektor med en linjelaser monteret deri |
| US16/312,485 US10893916B2 (en) | 2016-06-21 | 2017-06-20 | End effector having line laser mounted therein |
| JP2018566513A JP6646766B2 (ja) | 2016-06-21 | 2017-06-20 | ラインレーザーを搭載したエンドエフェクタ |
| CN201780039107.9A CN109310482B (zh) | 2016-06-21 | 2017-06-20 | 其中配备有线激光器的末端执行器 |
| PCT/KR2017/006457 WO2017222274A2 (ko) | 2016-06-21 | 2017-06-20 | 라인레이저가 장착된 엔드이펙터 |
| EP17815687.3A EP3473203B1 (en) | 2016-06-21 | 2017-06-20 | End effector having line laser mounted therein |
Applications Claiming Priority (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| KR1020160077615A KR102530305B1 (ko) | 2016-06-21 | 2016-06-21 | 라인레이저가 장착된 엔드이펙터 |
Publications (2)
| Publication Number | Publication Date |
|---|---|
| KR20170143397A true KR20170143397A (ko) | 2017-12-29 |
| KR102530305B1 KR102530305B1 (ko) | 2023-05-10 |
Family
ID=60783534
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| KR1020160077615A Active KR102530305B1 (ko) | 2016-06-21 | 2016-06-21 | 라인레이저가 장착된 엔드이펙터 |
Country Status (7)
| Country | Link |
|---|---|
| US (1) | US10893916B2 (ko) |
| EP (1) | EP3473203B1 (ko) |
| JP (1) | JP6646766B2 (ko) |
| KR (1) | KR102530305B1 (ko) |
| CN (1) | CN109310482B (ko) |
| DK (1) | DK3473203T3 (ko) |
| WO (1) | WO2017222274A2 (ko) |
Cited By (1)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| KR20200109502A (ko) | 2019-03-13 | 2020-09-23 | 큐렉소 주식회사 | 수술용 로봇의 엔드이펙터 |
Families Citing this family (9)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN109009485A (zh) * | 2018-09-12 | 2018-12-18 | 青岛梅德厚普医疗科技有限公司 | 一种手术辅助定位装置 |
| CN109893222B (zh) * | 2019-02-28 | 2024-02-13 | 成都真实维度科技有限公司 | 一种用于介入消融的植入性治疗激光定位的穿刺引导器 |
| CN110151326B (zh) * | 2019-06-27 | 2024-08-13 | 北京市神经外科研究所 | 激光导航器、外科手术机器人及激光束方向校准方法 |
| CN110882045B (zh) * | 2019-12-20 | 2024-12-24 | 车旭 | 一种用于超声穿刺的激光导向器及导向装置 |
| CN112336432A (zh) * | 2020-11-10 | 2021-02-09 | 亿盛欣科技(北京)有限公司 | 一种主从式ct透视引导实时穿刺系统及主从操作方法 |
| CN112336433B (zh) * | 2020-11-10 | 2022-04-08 | 亿盛欣科技(北京)有限公司 | 用于指示手术器械作用位置的装置、使用方法及标定方法 |
| CN115553888B (zh) * | 2022-10-28 | 2026-07-17 | 苏州派尼迩医疗科技有限公司 | 集3d相机、进针装置于一体的穿刺机器人及穿刺方法 |
| CN115778445B (zh) * | 2022-12-07 | 2025-05-16 | 佗道医疗科技有限公司 | 一种机械臂末端激光指引验证方法 |
| CN119235460B (zh) * | 2024-09-27 | 2025-10-03 | 山东威高手术机器人有限公司 | 一种腔镜手术机器人及其术前定位方法 |
Citations (3)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| US20100106056A1 (en) * | 2008-10-23 | 2010-04-29 | Norris Perry R | Methods for medical device alignment |
| US20100323320A1 (en) * | 2008-02-28 | 2010-12-23 | Akira Takebayashi | Surgical guide and a method for positioning a drill using the surgical guide |
| KR20150000232A (ko) * | 2013-06-24 | 2015-01-02 | 현대중공업 주식회사 | 중재시술용 바늘 삽입 엔드이펙터 |
Family Cites Families (11)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| US5316014A (en) * | 1992-02-07 | 1994-05-31 | Livingston Products, Inc. | Biopsy locator and guide |
| US5957933A (en) * | 1997-11-28 | 1999-09-28 | Picker International, Inc. | Interchangeable guidance devices for C.T. assisted surgery and method of using same |
| JP3637025B2 (ja) * | 2002-03-07 | 2005-04-06 | 株式会社日立製作所 | ツール位置提示システム及びこれを利用したツール位置提示方法、並びに、そのためのツール及びレーザー光照射角度演算方法 |
| JP4329431B2 (ja) * | 2003-07-14 | 2009-09-09 | 株式会社日立製作所 | 位置計測装置 |
| JP4425593B2 (ja) * | 2003-09-26 | 2010-03-03 | テルモ株式会社 | 穿刺器具および穿刺器具用光照射装置 |
| CN201008561Y (zh) * | 2007-03-09 | 2008-01-23 | 倪家骧 | 医用穿刺激光引导装置 |
| US20140107473A1 (en) * | 2012-10-17 | 2014-04-17 | Cincinnati Children's Hospital Medical Center | Laser Guidance System for Interventions |
| KR20140056772A (ko) | 2012-10-31 | 2014-05-12 | 현대중공업 주식회사 | 바늘삽입로봇의 바늘삽입 힘 제어시스템 및 제어방법 |
| KR101511299B1 (ko) | 2013-05-16 | 2015-04-13 | 재단법인 아산사회복지재단 | 생검 바늘 가이드 장치 |
| EP3102142A1 (en) * | 2014-02-04 | 2016-12-14 | Koninklijke Philips N.V. | Remote center of motion definition using light sources for robot systems |
| DE102014010994A1 (de) * | 2014-07-29 | 2016-02-04 | Elmako Gmbh & Co. Kg | Vorrichtung zur Benutzung in der Kryotherapie |
-
2016
- 2016-06-21 KR KR1020160077615A patent/KR102530305B1/ko active Active
-
2017
- 2017-06-20 DK DK17815687.3T patent/DK3473203T3/da active
- 2017-06-20 US US16/312,485 patent/US10893916B2/en active Active
- 2017-06-20 EP EP17815687.3A patent/EP3473203B1/en active Active
- 2017-06-20 JP JP2018566513A patent/JP6646766B2/ja active Active
- 2017-06-20 WO PCT/KR2017/006457 patent/WO2017222274A2/ko not_active Ceased
- 2017-06-20 CN CN201780039107.9A patent/CN109310482B/zh active Active
Patent Citations (3)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| US20100323320A1 (en) * | 2008-02-28 | 2010-12-23 | Akira Takebayashi | Surgical guide and a method for positioning a drill using the surgical guide |
| US20100106056A1 (en) * | 2008-10-23 | 2010-04-29 | Norris Perry R | Methods for medical device alignment |
| KR20150000232A (ko) * | 2013-06-24 | 2015-01-02 | 현대중공업 주식회사 | 중재시술용 바늘 삽입 엔드이펙터 |
Cited By (1)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| KR20200109502A (ko) | 2019-03-13 | 2020-09-23 | 큐렉소 주식회사 | 수술용 로봇의 엔드이펙터 |
Also Published As
| Publication number | Publication date |
|---|---|
| EP3473203A2 (en) | 2019-04-24 |
| JP6646766B2 (ja) | 2020-02-14 |
| WO2017222274A2 (ko) | 2017-12-28 |
| KR102530305B1 (ko) | 2023-05-10 |
| CN109310482B (zh) | 2021-05-18 |
| EP3473203B1 (en) | 2021-12-22 |
| JP2019520140A (ja) | 2019-07-18 |
| WO2017222274A3 (ko) | 2018-02-15 |
| US10893916B2 (en) | 2021-01-19 |
| US20190142543A1 (en) | 2019-05-16 |
| CN109310482A (zh) | 2019-02-05 |
| EP3473203A4 (en) | 2019-07-10 |
| DK3473203T3 (da) | 2022-01-24 |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| JP6646766B2 (ja) | ラインレーザーを搭載したエンドエフェクタ | |
| US12178537B2 (en) | Systems for defining and modifying range of motion of probe used in patient treatment | |
| JP3730274B2 (ja) | 手術支援システム | |
| CN110025379B (zh) | 一种超声图像与ct图像融合实时导航系统及方法 | |
| US20220409291A1 (en) | Planning and real-time updating a 3d trajectory of a medical instrument | |
| US11399901B2 (en) | Image guided robotic system for tumor aspiration | |
| KR20200085762A (ko) | 연조직에 대한 최소 절개 의료 개입을 위한 로봇 장치 | |
| WO2020100015A1 (en) | System for renal puncturing assistance | |
| CN212521854U (zh) | 一种医疗器械 | |
| CN108135563A (zh) | 光和阴影引导的针定位系统和方法 | |
| JP2006149560A (ja) | 核磁気共鳴撮像装置 | |
| US20260090856A1 (en) | Robotic collision boundary determination | |
| TWI849836B (zh) | 脊椎內視鏡用多軸定位輔助醫療裝置 | |
| JP3857710B2 (ja) | 手術支援システム | |
| JP2023508915A5 (ko) | ||
| US20250040987A1 (en) | Method for indicating an incision trajectory by a laser of an intraoperative imaging system | |
| Sugiyama et al. | Reaction force analysis of puncture robot for CT-guided Interventional Radiology in animal experiment | |
| Goto et al. | Feasibility of using the potassium titanyl phosphate laser with micromanipulators in robotic neurosurgery: a preliminary study in the rat |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| PA0109 | Patent application |
St.27 status event code: A-0-1-A10-A12-nap-PA0109 |
|
| N231 | Notification of change of applicant | ||
| PN2301 | Change of applicant |
St.27 status event code: A-3-3-R10-R13-asn-PN2301 St.27 status event code: A-3-3-R10-R11-asn-PN2301 |
|
| P11-X000 | Amendment of application requested |
St.27 status event code: A-2-2-P10-P11-nap-X000 |
|
| P13-X000 | Application amended |
St.27 status event code: A-2-2-P10-P13-nap-X000 |
|
| PG1501 | Laying open of application |
St.27 status event code: A-1-1-Q10-Q12-nap-PG1501 |
|
| A201 | Request for examination | ||
| PA0201 | Request for examination |
St.27 status event code: A-1-2-D10-D11-exm-PA0201 |
|
| E902 | Notification of reason for refusal | ||
| PE0902 | Notice of grounds for rejection |
St.27 status event code: A-1-2-D10-D21-exm-PE0902 |
|
| E13-X000 | Pre-grant limitation requested |
St.27 status event code: A-2-3-E10-E13-lim-X000 |
|
| P11-X000 | Amendment of application requested |
St.27 status event code: A-2-2-P10-P11-nap-X000 |
|
| P13-X000 | Application amended |
St.27 status event code: A-2-2-P10-P13-nap-X000 |
|
| E701 | Decision to grant or registration of patent right | ||
| PE0701 | Decision of registration |
St.27 status event code: A-1-2-D10-D22-exm-PE0701 |
|
| PR0701 | Registration of establishment |
St.27 status event code: A-2-4-F10-F11-exm-PR0701 |
|
| PR1002 | Payment of registration fee |
St.27 status event code: A-2-2-U10-U11-oth-PR1002 Fee payment year number: 1 |
|
| PG1601 | Publication of registration |
St.27 status event code: A-4-4-Q10-Q13-nap-PG1601 |
|
| R18-X000 | Changes to party contact information recorded |
St.27 status event code: A-5-5-R10-R18-oth-X000 |