KR20180135366A - 보행 보조 로봇 - Google Patents
보행 보조 로봇 Download PDFInfo
- Publication number
- KR20180135366A KR20180135366A KR1020170073389A KR20170073389A KR20180135366A KR 20180135366 A KR20180135366 A KR 20180135366A KR 1020170073389 A KR1020170073389 A KR 1020170073389A KR 20170073389 A KR20170073389 A KR 20170073389A KR 20180135366 A KR20180135366 A KR 20180135366A
- Authority
- KR
- South Korea
- Prior art keywords
- user
- harness
- joint
- walking
- pair
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Granted
Links
Images




Classifications
-
- A—HUMAN NECESSITIES
- A61—MEDICAL OR VETERINARY SCIENCE; HYGIENE
- A61H—PHYSICAL THERAPY APPARATUS, e.g. DEVICES FOR LOCATING OR STIMULATING REFLEX POINTS IN THE BODY; ARTIFICIAL RESPIRATION; MASSAGE; BATHING DEVICES FOR SPECIAL THERAPEUTIC OR HYGIENIC PURPOSES OR SPECIFIC PARTS OF THE BODY
- A61H3/00—Appliances for aiding patients or disabled persons to walk about
- A61H3/008—Appliances for aiding patients or disabled persons to walk about using suspension devices for supporting the body in an upright walking or standing position, e.g. harnesses
-
- A—HUMAN NECESSITIES
- A61—MEDICAL OR VETERINARY SCIENCE; HYGIENE
- A61H—PHYSICAL THERAPY APPARATUS, e.g. DEVICES FOR LOCATING OR STIMULATING REFLEX POINTS IN THE BODY; ARTIFICIAL RESPIRATION; MASSAGE; BATHING DEVICES FOR SPECIAL THERAPEUTIC OR HYGIENIC PURPOSES OR SPECIFIC PARTS OF THE BODY
- A61H1/00—Apparatus for passive exercising; Vibrating apparatus; Chiropractic devices, e.g. body impacting devices, external devices for briefly extending or aligning unbroken bones
- A61H1/02—Stretching or bending or torsioning apparatus for exercising
- A61H1/0237—Stretching or bending or torsioning apparatus for exercising for the lower limbs
- A61H1/0255—Both knee and hip of a patient, e.g. in supine or sitting position, the feet being moved together in a plane substantially parallel to the body-symmetrical plane
- A61H1/0262—Walking movement; Appliances for aiding disabled persons to walk
-
- A—HUMAN NECESSITIES
- A61—MEDICAL OR VETERINARY SCIENCE; HYGIENE
- A61H—PHYSICAL THERAPY APPARATUS, e.g. DEVICES FOR LOCATING OR STIMULATING REFLEX POINTS IN THE BODY; ARTIFICIAL RESPIRATION; MASSAGE; BATHING DEVICES FOR SPECIAL THERAPEUTIC OR HYGIENIC PURPOSES OR SPECIFIC PARTS OF THE BODY
- A61H3/00—Appliances for aiding patients or disabled persons to walk about
- A61H3/04—Wheeled walking aids for patients or disabled persons
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B25—HAND TOOLS; PORTABLE POWER-DRIVEN TOOLS; MANIPULATORS
- B25J—MANIPULATORS; CHAMBERS PROVIDED WITH MANIPULATION DEVICES
- B25J11/00—Manipulators not otherwise provided for
- B25J11/008—Manipulators for service tasks
- B25J11/009—Nursing, e.g. carrying sick persons, pushing wheelchairs, distributing drugs
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B25—HAND TOOLS; PORTABLE POWER-DRIVEN TOOLS; MANIPULATORS
- B25J—MANIPULATORS; CHAMBERS PROVIDED WITH MANIPULATION DEVICES
- B25J9/00—Program-controlled manipulators
- B25J9/0006—Exoskeletons, i.e. resembling a human figure
-
- A—HUMAN NECESSITIES
- A61—MEDICAL OR VETERINARY SCIENCE; HYGIENE
- A61H—PHYSICAL THERAPY APPARATUS, e.g. DEVICES FOR LOCATING OR STIMULATING REFLEX POINTS IN THE BODY; ARTIFICIAL RESPIRATION; MASSAGE; BATHING DEVICES FOR SPECIAL THERAPEUTIC OR HYGIENIC PURPOSES OR SPECIFIC PARTS OF THE BODY
- A61H3/00—Appliances for aiding patients or disabled persons to walk about
- A61H2003/007—Appliances for aiding patients or disabled persons to walk about secured to the patient, e.g. with belts
-
- A—HUMAN NECESSITIES
- A61—MEDICAL OR VETERINARY SCIENCE; HYGIENE
- A61H—PHYSICAL THERAPY APPARATUS, e.g. DEVICES FOR LOCATING OR STIMULATING REFLEX POINTS IN THE BODY; ARTIFICIAL RESPIRATION; MASSAGE; BATHING DEVICES FOR SPECIAL THERAPEUTIC OR HYGIENIC PURPOSES OR SPECIFIC PARTS OF THE BODY
- A61H2201/00—Characteristics of apparatus not provided for in the preceding codes
- A61H2201/16—Physical interface with patient
- A61H2201/1602—Physical interface with patient kind of interface, e.g. head rest, knee support or lumbar support
- A61H2201/165—Wearable interfaces
- A61H2201/1652—Harness
Landscapes
- Health & Medical Sciences (AREA)
- General Health & Medical Sciences (AREA)
- Engineering & Computer Science (AREA)
- Public Health (AREA)
- Rehabilitation Therapy (AREA)
- Life Sciences & Earth Sciences (AREA)
- Animal Behavior & Ethology (AREA)
- Physical Education & Sports Medicine (AREA)
- Pain & Pain Management (AREA)
- Veterinary Medicine (AREA)
- Epidemiology (AREA)
- Robotics (AREA)
- Mechanical Engineering (AREA)
- Nursing (AREA)
- Orthopedic Medicine & Surgery (AREA)
- Rehabilitation Tools (AREA)
Abstract
Description
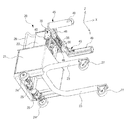
도 2 및 도 3은 도 1의 본체의 사시도로서, 도 2는 위에서 본 도면이고, 도 3은 아래에서 본 도면이다.
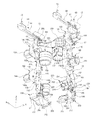
도 4 및 도 5는 도 1의 좌측 및 우측 하지 외골격을 도시한 사시도로서, 도 4는 위에서 보고 도시한 도면이고, 도 5는 아래에서 보고 도시한 도면이다.
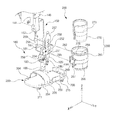
도 6은 도 4의 우측 하지 외골격의 대퇴부 하네스의 분해 사시도이다.
도 7은 도 4의 우측 하지 외골격의 정강이 하네스의 분해 사시도이다.
도 8은 도 1의 보행 보조 로봇의 기능 구현을 위한 구성의 일 예를 도시한 블록도이다.
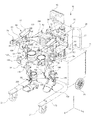
24: 구동 휠 30: 승강체
60: 하지 외골격 100: 제1 관절
140: 제2 관절 180: 제3 관절
200: 발판 220: 대퇴부 하네스
250: 정강이 하네스 280: 허리 지지대
Claims (8)
- 사용자의 좌측 및 우측 다리에 착용되어 상기 좌측 및 우측 다리가 움직이도록 외력(外力)을 제공하는 좌측 및 우측 하지 외골격; 및, 상기 좌측 및 우측 하지 외골격을 지지하며 진행하는 본체;를 구비하고,
상기 좌측 및 우측 하지 외골격은 각각, 상기 사용자의 대퇴부에 착용되는 대퇴부 하네스(harness), 및 상기 사용자의 정강이에 착용되는 정강이 하네스를 구비하고,
상기 대퇴부 하네스는, 상기 대퇴부를 감싸도록 둥글게 말린 제1 랩핑 프레임(wrapping frame), 및 상기 제1 랩핑 프레임의 내주면에 착탈 가능하게 부착되며, 적어도 상기 대퇴부에 접촉되는 부분은 옷감으로 이루어진 제1 내피를 구비하고,
상기 정강이 하네스는, 상기 정강이를 감싸도록 둥글게 말린 제2 랩핑 프레임, 및 상기 제2 랩핑 프레임의 내주면에 착탈 가능하게 부착되며, 적어도 상기 정강이에 접촉되는 부분은 옷감으로 이루어진 제2 내피를 구비하는 것을 특징으로 하는 보행 보조 로봇. - 제1 항에 있어서,
상기 사용자의 대퇴부의 굵기 및 정강이의 굵기에 맞춰 상기 제1 랩핑 프레임 및 상기 제2 랩핑 프레임의 곡률이 조정되는 것을 특징으로 하는 보행 보조 로봇. - 제1 항에 있어서,
상기 좌측 및 우측 하지 외골격은 각각, 상기 사용자의 고관절(coxa)이 회전하도록 동력 회전하는 제1 관절(joint), 상기 사용자의 무릎 관절이 회전하도록 동력 회전하는 제2 관절, 상기 사용자의 발을 지지하는 발판, 상기 사용자의 발목 주변에 위치하며 상기 발판을 고정 지지하는 제3 관절, 상기 제1 관절과 상기 제2 관절을 연결하는 제1 기둥, 및 상기 제2 관절과 상기 제3 관절을 연결하는 제2 기둥을 구비하는 것을 특징으로 하는 보행 보조 로봇. - 제3 항에 있어서,
상기 대퇴부 하네스는, 상기 제2 관절에 고정 체결되고, 상향 연장된 브라켓 지지체, 상기 제1 랩핑 프레임에 고정 체결되고, 상기 브라켓 지지체의 상측부에 체결 지지되는 제1 하네스 브라켓(bracket)을 구비하는 것을 특징으로 하는 보행 보조 로봇. - 제3 항에 있어서,
상기 정강이 하네스는, 상기 제3 관절에 고정된 하네스 클램퍼(clamper), 상기 제2 랩핑 프레임에 고정 체결되고, 상기 하네스 클램퍼에 상하 방향으로 위치 조정 가능하게 지지되는 제2 하네스 브라켓을 구비하는 것을 특징으로 하는 보행 보조 로봇. - 제5 항에 있어서,
제2 하네스 브라켓의 일 측면에는 상기 하네스 클램퍼에 대한 상기 제2 하네스 브라켓의 높이를 알려주는 눈금(gradation)이 표시된 것을 특징으로 하는 보행 보조 로봇. - 제1 항에 있어서,
상기 사용자의 허리 배면부(背面部)를 받쳐 주는 것으로, 좌측 및 우측 단부가 상기 좌측 및 우측 하지 외골격에 고정 체결된 허리 지지대;를 더 구비하는 것을 특징으로 하는 보행 보조 로봇. - 제1 항에 있어서,
상기 제1 및 제2 내피를 상기 제1 및 제2 랩핑 프레임에 착탈 가능하게 부착시키는 수단은 벨크로 테이프(Velcro tape)인 것을 특징으로 하는 보행 보조 로봇.
Priority Applications (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| KR1020170073389A KR101988644B1 (ko) | 2017-06-12 | 2017-06-12 | 보행 보조 로봇 |
Applications Claiming Priority (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| KR1020170073389A KR101988644B1 (ko) | 2017-06-12 | 2017-06-12 | 보행 보조 로봇 |
Publications (2)
| Publication Number | Publication Date |
|---|---|
| KR20180135366A true KR20180135366A (ko) | 2018-12-20 |
| KR101988644B1 KR101988644B1 (ko) | 2019-06-12 |
Family
ID=64952895
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| KR1020170073389A Expired - Fee Related KR101988644B1 (ko) | 2017-06-12 | 2017-06-12 | 보행 보조 로봇 |
Country Status (1)
| Country | Link |
|---|---|
| KR (1) | KR101988644B1 (ko) |
Cited By (7)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| KR102162455B1 (ko) * | 2019-07-01 | 2020-10-08 | 주식회사 헥사휴먼케어 | 확장형 착용로봇 시스템 |
| KR20200145547A (ko) | 2019-06-21 | 2020-12-30 | 서지오 | 생태효과조사를 위한 방형구형 천연채묘장치 |
| WO2021002663A1 (ko) * | 2019-07-01 | 2021-01-07 | 주식회사 헥사휴먼케어 | 보행 자동화 로봇 시스템 |
| WO2021261701A1 (ko) * | 2020-06-26 | 2021-12-30 | 삼성전자주식회사 | 운동 보조 장치용 홀더 |
| CN115998572A (zh) * | 2021-10-22 | 2023-04-25 | 深圳市奇诺动力科技有限公司 | 一种步态训练装置及其控制方法 |
| CN116833976A (zh) * | 2022-03-24 | 2023-10-03 | 广州视鹏科技有限公司 | 一种腿部组件及外附骨骼 |
| CN119897879A (zh) * | 2025-02-12 | 2025-04-29 | 中国人民解放军总医院第二医学中心 | 一种老年康复护理服务机器人 |
Families Citing this family (1)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| KR102123694B1 (ko) * | 2019-11-25 | 2020-06-16 | 엑소아틀레트아시아 주식회사 | 보행보조 웨어러블 로봇장치 |
Citations (5)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JPH0313512U (ko) * | 1989-06-20 | 1991-02-12 | ||
| KR100716597B1 (ko) * | 2005-12-30 | 2007-05-09 | 서강대학교산학협력단 | 지능형 근력 및 보행 보조용 로봇 |
| JP4315766B2 (ja) * | 2003-05-21 | 2009-08-19 | 本田技研工業株式会社 | 歩行補助装置 |
| JP5075759B2 (ja) * | 2008-08-07 | 2012-11-21 | 本田技研工業株式会社 | 歩行補助装置 |
| KR101221046B1 (ko) | 2010-11-26 | 2013-02-13 | 주식회사 바이오닉스 | 지능형 외골격 로봇기반의 일상생활 보조 및 재활훈련 시스템 |
-
2017
- 2017-06-12 KR KR1020170073389A patent/KR101988644B1/ko not_active Expired - Fee Related
Patent Citations (5)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JPH0313512U (ko) * | 1989-06-20 | 1991-02-12 | ||
| JP4315766B2 (ja) * | 2003-05-21 | 2009-08-19 | 本田技研工業株式会社 | 歩行補助装置 |
| KR100716597B1 (ko) * | 2005-12-30 | 2007-05-09 | 서강대학교산학협력단 | 지능형 근력 및 보행 보조용 로봇 |
| JP5075759B2 (ja) * | 2008-08-07 | 2012-11-21 | 本田技研工業株式会社 | 歩行補助装置 |
| KR101221046B1 (ko) | 2010-11-26 | 2013-02-13 | 주식회사 바이오닉스 | 지능형 외골격 로봇기반의 일상생활 보조 및 재활훈련 시스템 |
Cited By (11)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| KR20200145547A (ko) | 2019-06-21 | 2020-12-30 | 서지오 | 생태효과조사를 위한 방형구형 천연채묘장치 |
| KR102162455B1 (ko) * | 2019-07-01 | 2020-10-08 | 주식회사 헥사휴먼케어 | 확장형 착용로봇 시스템 |
| WO2021002663A1 (ko) * | 2019-07-01 | 2021-01-07 | 주식회사 헥사휴먼케어 | 보행 자동화 로봇 시스템 |
| WO2021002662A1 (ko) * | 2019-07-01 | 2021-01-07 | 주식회사 헥사휴먼케어 | 확장형 착용로봇 시스템 |
| KR20210011084A (ko) * | 2019-07-01 | 2021-02-01 | 주식회사 헥사휴먼케어 | 보행 자동화 로봇 시스템 |
| WO2021261701A1 (ko) * | 2020-06-26 | 2021-12-30 | 삼성전자주식회사 | 운동 보조 장치용 홀더 |
| US12427355B2 (en) | 2020-06-26 | 2025-09-30 | Samsung Electronics Co., Ltd. | Holder for exercise assistance device |
| CN115998572A (zh) * | 2021-10-22 | 2023-04-25 | 深圳市奇诺动力科技有限公司 | 一种步态训练装置及其控制方法 |
| CN116833976A (zh) * | 2022-03-24 | 2023-10-03 | 广州视鹏科技有限公司 | 一种腿部组件及外附骨骼 |
| CN116833976B (zh) * | 2022-03-24 | 2024-05-31 | 广州视鹏科技有限公司 | 一种腿部组件及外附骨骼 |
| CN119897879A (zh) * | 2025-02-12 | 2025-04-29 | 中国人民解放军总医院第二医学中心 | 一种老年康复护理服务机器人 |
Also Published As
| Publication number | Publication date |
|---|---|
| KR101988644B1 (ko) | 2019-06-12 |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| KR101988644B1 (ko) | 보행 보조 로봇 | |
| KR102334854B1 (ko) | 보행 보조 로봇 | |
| KR101979938B1 (ko) | 보행 보조 로봇 | |
| KR101869968B1 (ko) | 하지 외골격을 구비한 보행 보조 로봇 | |
| KR102339664B1 (ko) | 운동 보조 장치 및 그 제어 방법 | |
| KR101227861B1 (ko) | 상지근력보조기구 | |
| KR101913187B1 (ko) | 편마비 환자용 보행 보조장치 및 그 제어방법 | |
| US7322904B2 (en) | Lower limb function training device | |
| KR101368817B1 (ko) | 보행 보조장치 | |
| CN103200909B (zh) | 行动辅助设备 | |
| Choi et al. | Walkon suit: A medalist in the powered exoskeleton race of cybathlon 2016 | |
| US7641591B2 (en) | Lower limb function training device | |
| TW201639533A (zh) | 互動式外骨骼膝關節機器系統 | |
| CN112545846A (zh) | 一种基于意图识别的动力型多自由度助行下肢外骨骼机器人 | |
| CN114642573B (zh) | 一种康复用外骨骼 | |
| KR20180026692A (ko) | 하지 외골격을 구비한 보행 보조 로봇 | |
| CN110681121B (zh) | 一种骨科髋关节活动度锻炼用助行器 | |
| KR20190056592A (ko) | 발목보조장치 | |
| KR20140109090A (ko) | 다리 근력 재활장치 | |
| KR20230024499A (ko) | 재활훈련용 능동보행 보조로봇 | |
| KR101219305B1 (ko) | 보행보조용 플랫폼 | |
| KR101979937B1 (ko) | 보행 보조 로봇 | |
| KR100391830B1 (ko) | 보행장애인의 재활훈련을 위한 복지용 로봇 | |
| CN209899989U (zh) | 一种复合式外骨骼助行设备 | |
| KR102893991B1 (ko) | 하지 재활 훈련 로봇 시스템 및 이의 제어 방법 |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| A201 | Request for examination | ||
| PA0109 | Patent application |
St.27 status event code: A-0-1-A10-A12-nap-PA0109 |
|
| PA0201 | Request for examination |
St.27 status event code: A-1-2-D10-D11-exm-PA0201 |
|
| D13-X000 | Search requested |
St.27 status event code: A-1-2-D10-D13-srh-X000 |
|
| D14-X000 | Search report completed |
St.27 status event code: A-1-2-D10-D14-srh-X000 |
|
| E902 | Notification of reason for refusal | ||
| PE0902 | Notice of grounds for rejection |
St.27 status event code: A-1-2-D10-D21-exm-PE0902 |
|
| E13-X000 | Pre-grant limitation requested |
St.27 status event code: A-2-3-E10-E13-lim-X000 |
|
| P11-X000 | Amendment of application requested |
St.27 status event code: A-2-2-P10-P11-nap-X000 |
|
| P13-X000 | Application amended |
St.27 status event code: A-2-2-P10-P13-nap-X000 |
|
| PG1501 | Laying open of application |
St.27 status event code: A-1-1-Q10-Q12-nap-PG1501 |
|
| E90F | Notification of reason for final refusal | ||
| PE0902 | Notice of grounds for rejection |
St.27 status event code: A-1-2-D10-D21-exm-PE0902 |
|
| P11-X000 | Amendment of application requested |
St.27 status event code: A-2-2-P10-P11-nap-X000 |
|
| P13-X000 | Application amended |
St.27 status event code: A-2-2-P10-P13-nap-X000 |
|
| E701 | Decision to grant or registration of patent right | ||
| PE0701 | Decision of registration |
St.27 status event code: A-1-2-D10-D22-exm-PE0701 |
|
| GRNT | Written decision to grant | ||
| PR0701 | Registration of establishment |
St.27 status event code: A-2-4-F10-F11-exm-PR0701 |
|
| PR1002 | Payment of registration fee |
St.27 status event code: A-2-2-U10-U11-oth-PR1002 Fee payment year number: 1 |
|
| PG1601 | Publication of registration |
St.27 status event code: A-4-4-Q10-Q13-nap-PG1601 |
|
| R18-X000 | Changes to party contact information recorded |
St.27 status event code: A-5-5-R10-R18-oth-X000 |
|
| S20-X000 | Security interest recorded |
St.27 status event code: A-4-4-S10-S20-lic-X000 |
|
| PR1001 | Payment of annual fee |
St.27 status event code: A-4-4-U10-U11-oth-PR1001 Fee payment year number: 4 |
|
| PR1001 | Payment of annual fee |
St.27 status event code: A-4-4-U10-U11-oth-PR1001 Fee payment year number: 5 |
|
| S22-X000 | Recordation of security interest cancelled |
St.27 status event code: A-4-4-S10-S22-lic-X000 |
|
| P22-X000 | Classification modified |
St.27 status event code: A-4-4-P10-P22-nap-X000 |
|
| PC1903 | Unpaid annual fee |
St.27 status event code: A-4-4-U10-U13-oth-PC1903 Not in force date: 20240606 Payment event data comment text: Termination Category : DEFAULT_OF_REGISTRATION_FEE |
|
| K11-X000 | Ip right revival requested |
St.27 status event code: A-6-4-K10-K11-oth-X000 |
|
| PC1903 | Unpaid annual fee |
St.27 status event code: N-4-6-H10-H13-oth-PC1903 Ip right cessation event data comment text: Termination Category : DEFAULT_OF_REGISTRATION_FEE Not in force date: 20240606 |
|
| PR0401 | Registration of restoration |
St.27 status event code: A-6-4-K10-K13-oth-PR0401 |
|
| PR1001 | Payment of annual fee |
St.27 status event code: A-4-4-U10-U11-oth-PR1001 Fee payment year number: 6 |
|
| R401 | Registration of restoration | ||
| S20-X000 | Security interest recorded |
St.27 status event code: A-4-4-S10-S20-lic-X000 |
|
| PC1903 | Unpaid annual fee |
St.27 status event code: A-4-4-U10-U13-oth-PC1903 Not in force date: 20250606 Payment event data comment text: Termination Category : DEFAULT_OF_REGISTRATION_FEE |
|
| H13 | Ip right lapsed |
Free format text: ST27 STATUS EVENT CODE: N-4-6-H10-H13-OTH-PC1903 (AS PROVIDED BY THE NATIONAL OFFICE); TERMINATION CATEGORY : DEFAULT_OF_REGISTRATION_FEE Effective date: 20250606 |
|
| PC1903 | Unpaid annual fee |
St.27 status event code: N-4-6-H10-H13-oth-PC1903 Ip right cessation event data comment text: Termination Category : DEFAULT_OF_REGISTRATION_FEE Not in force date: 20250606 |