KR20200062880A - Robot for Removing Ice And Snow on Transmission Line - Google Patents
Robot for Removing Ice And Snow on Transmission Line Download PDFInfo
- Publication number
- KR20200062880A KR20200062880A KR1020180148811A KR20180148811A KR20200062880A KR 20200062880 A KR20200062880 A KR 20200062880A KR 1020180148811 A KR1020180148811 A KR 1020180148811A KR 20180148811 A KR20180148811 A KR 20180148811A KR 20200062880 A KR20200062880 A KR 20200062880A
- Authority
- KR
- South Korea
- Prior art keywords
- transmission line
- main body
- ice
- snow
- hub
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Granted
Links
- 230000005540 biological transmission Effects 0.000 title claims abstract description 146
- 238000004891 communication Methods 0.000 claims abstract description 14
- 238000005096 rolling process Methods 0.000 claims description 12
- 238000001514 detection method Methods 0.000 claims description 6
- 230000033001 locomotion Effects 0.000 claims description 5
- 238000003306 harvesting Methods 0.000 claims description 2
- 238000009434 installation Methods 0.000 abstract description 2
- 230000006378 damage Effects 0.000 description 6
- 238000012986 modification Methods 0.000 description 3
- 230000004048 modification Effects 0.000 description 3
- 230000002265 prevention Effects 0.000 description 3
- XEEYBQQBJWHFJM-UHFFFAOYSA-N Iron Chemical compound [Fe] XEEYBQQBJWHFJM-UHFFFAOYSA-N 0.000 description 2
- 229910052782 aluminium Inorganic materials 0.000 description 2
- XAGFODPZIPBFFR-UHFFFAOYSA-N aluminium Chemical compound [Al] XAGFODPZIPBFFR-UHFFFAOYSA-N 0.000 description 2
- 230000007613 environmental effect Effects 0.000 description 2
- 230000008014 freezing Effects 0.000 description 2
- 238000007710 freezing Methods 0.000 description 2
- 239000002783 friction material Substances 0.000 description 2
- 239000011347 resin Substances 0.000 description 2
- 229920005989 resin Polymers 0.000 description 2
- 208000027418 Wounds and injury Diseases 0.000 description 1
- 238000009825 accumulation Methods 0.000 description 1
- 238000007792 addition Methods 0.000 description 1
- 230000015572 biosynthetic process Effects 0.000 description 1
- 239000011248 coating agent Substances 0.000 description 1
- 238000000576 coating method Methods 0.000 description 1
- 238000005520 cutting process Methods 0.000 description 1
- 230000006866 deterioration Effects 0.000 description 1
- 238000010586 diagram Methods 0.000 description 1
- 208000014674 injury Diseases 0.000 description 1
- 229910052742 iron Inorganic materials 0.000 description 1
- 238000004519 manufacturing process Methods 0.000 description 1
- 229910052751 metal Inorganic materials 0.000 description 1
- 239000002184 metal Substances 0.000 description 1
- 238000000034 method Methods 0.000 description 1
- 238000007789 sealing Methods 0.000 description 1
- 238000006467 substitution reaction Methods 0.000 description 1
Images



Classifications
-
- H—ELECTRICITY
- H02—GENERATION; CONVERSION OR DISTRIBUTION OF ELECTRIC POWER
- H02G—INSTALLATION OF ELECTRIC CABLES OR LINES, OR OF COMBINED OPTICAL AND ELECTRIC CABLES OR LINES
- H02G7/00—Overhead installations of electric lines or cables
- H02G7/16—Devices for removing snow or ice from lines or cables
Landscapes
- Suspension Of Electric Lines Or Cables (AREA)
- Photovoltaic Devices (AREA)
- Buildings Adapted To Withstand Abnormal External Influences (AREA)
Abstract
본 발명은 송전선로에 일정량 이상의 적설량이 감지되면 자동으로 송전선로를 따라 이동하면서 송전선로에 쌓인 빙설을 제거할 수 있도록 하고, 간단한 구성과 적은 설치 비용으로 송전선로의 빙설을 효율적으로 제거하며, 필요시 무선통신을 통해 원격제어가 가능한 송전선로의 빙설 제거로봇에 관한 것으로, 본 발명의 한 형태에 따른 송전선로의 빙설 제거로봇은, 송전선로를 따라 이동 가능하게 설치되는 본체; 상기 본체에 송전선로와 밀착되게 설치되어 상기 본체가 송전선로를 따라 이동하도록 동력을 제공하는 구동부; 상기 본체에 설치되어 본체가 구동부에 의해 이동할 때 상기 송전선로에 쌓인 빙설과 접촉하면서 빙설을 제거하는 빙설제거부; 및, 상기 구동부의 작동을 제어하는 제어부;를 포함한다. The present invention makes it possible to remove ice and snow accumulated on the power transmission line while automatically moving along the power transmission line when a predetermined amount of snowfall is detected on the power transmission line, and efficiently remove the snow and ice on the power transmission line with a simple configuration and low installation cost. Regarding a snow and snow removal robot of a transmission line that can be remotely controlled through a city wireless communication, the ice and snow removal robot of a transmission line according to one embodiment of the present invention includes a main body installed to be movable along a transmission line; A driving unit installed in close contact with the transmission line in the main body to provide power to move the main body along the transmission line; An ice and snow removal unit installed on the main body to remove ice and snow while contacting ice and ice accumulated on the power transmission line when the main body is moved by the driving unit; And a control unit controlling operation of the driving unit.
Description
본 발명은 송전선로의 빙설을 제거하는 장치에 관한 것으로, 더욱 상세하게는 송전선로 상의 적설량을 감지하여 적설량이 일정량 이상이 되면 자동으로 송전선로를 따라 이동하면서 송전선로에 퇴적된 빙설을 제거하며, 필요시 무선통신을 통해 원격제어가 가능한 송전선로의 빙설 제거로봇에 관한 것이다. The present invention relates to an apparatus for removing ice and snow from a power transmission line, and more specifically, detecting snow load on the power transmission line and automatically moving along the power transmission line when the snow load exceeds a certain amount, removing ice and snow accumulated on the power transmission line, It relates to a snow and ice removal robot of a transmission line that can be remotely controlled through wireless communication when necessary.
전력 송전선인 가공송전선은 지상으로부터 공중으로 일정거리 이격되어 철탑에 의해 전력을 전송하는 것으로, 일반적으로 발전소에서 발생된 전력을 변전소 등에 보내기 위해 사용되고 있다. 가공송전선은 외부 환경에 그대로 노출되어 있어서 기후에 의한 영향을 상대적으로 많이 받을 수 있다. 특히 기온이 낮고 바람이 심한 겨울의 산간지역의 송전선로나 혹은 위도가 높은 극지방 지대와 같은 혹한지역은 송전선로에 착빙과 결빙이 수시로 발생하여 송전선의 하중을 크게 증가시켜 회손 및 절단 등의 피해가 빈번히 발생하고 있으며 복구 작업에 많은 시간과 비용을 초래하고 있는 실정이다.The overhead power transmission line, which is an electric power transmission line, is spaced a certain distance from the ground to the air to transmit electric power by a pylon, and is generally used to send power generated by a power plant to a substation or the like. The overhead power transmission line is exposed to the external environment, so it can be relatively affected by the weather. In particular, in cold regions such as low-temperature, windy winter mountainous regions or high-latitude polar regions, icing and freezing occur frequently on the transmission line, which greatly increases the load on the transmission line, frequently causing damages such as damage and cutting. It is happening and causing a lot of time and money to recover.
이에 따라 현재로선 제설이 필요한 지역에 사람이 직접 올라가 제설작업을 하고 있지만, 송전선로의 환경 특성상 인력으로 작업하기 매우 위험하기 때문에 잦은 안전사고가 발생하고 있다. 특히 착빙과 결빙이 수시로 발생하는 산간지역의 송전선로의 경우 일단 안전사고가 일어나면 인명피해로 직결되기 때문에 이에 따른 해결책이 반드시 필요하다.Accordingly, at present, a person directly climbs to the area where snow removal is needed, but due to the environmental characteristics of the transmission line, it is very dangerous to work as a man, so frequent safety accidents occur. In particular, in the case of a transmission line in a mountainous area where icing and freezing occur frequently, a solution is necessary because a safety accident directly leads to human injury.
이와 같은 문제점을 해결하기 위해 나왔던 선행기술들의 한계점은 다음과 같다.The limitations of the prior art that came out to solve this problem are as follows.
등록특허 제10-1554983호는 알루미늄 송전선을 표면 개질 시킨 후, 여기에 나노하이브리드 절연수지를 코팅하여 발수성(hydrophobicity)을 일정 수준으로 향상시켜 동절기 시 우천 및 착빙에 의한 송전선의 폐손을 방지할 수 있는 "착빙설이 방지되는 알루미늄 송전선의 제조방법"을 개시하고 있다.Registered Patent No. 10-1554983, after surface modification of the aluminum transmission line, coated with a nano-hybrid insulating resin to improve the hydrophobicity to a certain level to prevent damage to the transmission line due to rain and icing during winter season. Disclosed is a method of manufacturing an aluminum transmission line that prevents ice formation.
그러나 상기한 송전선은 비용 대비 효율이 적고, 송전선 표면의 코팅이 마모될 경우 다시 코팅해야 하는 문제가 있으며, 기존 송전선에는 적용할 수 없어 송전선을 새로 설치해야 하는 문제가 있다. However, the above-described transmission line has a low cost-effectiveness, and there is a problem in that the coating on the surface of the transmission line must be re-coated, and there is a problem that a transmission line must be newly installed because it cannot be applied to an existing transmission line.
또한 등록특허 제10-1599267호에는 송전선로에 진동을 가하여 송전선로에 부착된 빙설을 제거할 수 있도록 한 "송전선로 빙설 제거장치"가 개시되어 있다. In addition, Patent No. 10-1599267 discloses a "transmission line ice and snow removal device" that allows vibration to be applied to a transmission line to remove ice and snow attached to the transmission line.
그러나 상기한 등록특허의 송전선로 빙설 제거장치는 진동에 의해 송전선이 크게 흔들려 선간 혼촉, 비틀림에 의한 파손 위험이 있으며, 제설이 필요한 부분이 제한적일 때도 동일한 전력을 사용해야 하므로 전력손실이 큰 문제가 있어 적용되고 있지 못하고 있다.However, the transmission line ice and snow removal device of the above-mentioned registered patent has a risk of damage due to contact and twisting between lines due to the large fluctuation of the transmission line due to vibration. It is not becoming.
공개특허 제10-2018-0032073호에는 복수 개의 소선들이 꼬아져 구성된 송전선의 외주를 둘러싸는 난착빙설 방지장치로서, 철손에 의해 열을 발생시키는 연자성금속링에 실링패드와 매뉴폴더를 적용하여 일체화함으로써 송전선을 안정적으로 장악함과 동시에 소선과 소선의 꼬임 사이에 빙설고착을 방지하는 "난착빙설 방지장치"를 개시하고 있다.Patent Publication No. 10-2018-0032073 is a device for preventing ice and snow from surrounding a circumference of a power transmission line composed of a plurality of twisted wires, integrated by applying a sealing pad and a manifold to a soft magnetic metal ring that generates heat by iron loss. By doing so, it has been disclosed a "prevention of ice and snow prevention device" which securely controls the power transmission line and prevents ice and ice fixation between the wire and the twist of the wire.
그러나, 상기 난착빙설 방지장치는 사용 재료가 자외선에 의한 열화에 취약하며, 전선의 비틀림에 의한 파손의 위험이 있고, 제설 효과 면적이 작아 송전선에 많은 수의 난착빙설 방지장치를 설치해야 하므로 비용이 많이 드는 문제가 있다.However, the device for preventing ice and snow from being damaged is vulnerable to deterioration due to ultraviolet rays, and there is a risk of damage due to twisting of the electric wire, and since the snow removal area is small, a large number of ice and snow prevention devices need to be installed on the transmission line. There is a lot of trouble.
본 발명은 상기한 문제를 해결하기 위한 것으로, 본 발명의 목적은 송전선로에 일정량 이상의 적설량이 감지되면 자동으로 송전선로를 따라 이동하면서 송전선로에 쌓인 빙설을 제거할 수 있도록 하고, 필요시 무선통신을 통해 원격제어가 가능하며, 간단한 구성과 적은 설치 비용으로 송전선로의 빙설을 효율적으로 제거할 수 있는 송전선로의 빙설 제거로봇을 제공함에 있다.The present invention is to solve the above problems, the object of the present invention is to automatically remove the ice and snow accumulated on the transmission line while moving along the transmission line when a certain amount of snowfall is detected on the transmission line, and if necessary, wireless communication The present invention provides a robot for removing ice and snow from the power transmission line, which can be remotely controlled and can efficiently remove the snow and ice from the power transmission line with a simple configuration and low installation cost.
상기한 목적을 달성하기 위한 본 발명의 한 형태에 따른 송전선로의 빙설 제거로봇은, 송전선로를 따라 이동 가능하게 설치되는 본체; 상기 본체에 송전선로와 밀착되게 설치되어 상기 본체가 송전선로를 따라 이동하도록 동력을 제공하는 구동부; 상기 본체에 설치되어 본체가 구동부에 의해 이동할 때 상기 송전선로에 쌓인 빙설과 접촉하면서 빙설을 제거하는 빙설제거부; 및, 상기 구동부의 작동을 제어하는 제어부;를 포함한다. To achieve the above object, a snow and ice removal robot for a transmission line according to one aspect of the present invention includes a main body that is movably installed along a transmission line; A driving unit installed in close contact with the transmission line in the main body to provide power to move the main body along the transmission line; An ice and snow removal unit installed on the main body to remove ice and snow while contacting ice and ice accumulated on the power transmission line when the main body is moved by the driving unit; And a control unit controlling operation of the driving unit.
본 발명의 빙설 제거로봇은, 상기 본체의 상부에 설치되어 본체의 상부에 쌓이는 빙설의 적설량을 감지하고 감지 신호를 상기 제어부로 전송하는 적설량 센서를 더 포함할 수 있다. The ice removal robot of the present invention may further include a snowfall sensor installed on an upper portion of the main body to detect the amount of snowfall accumulated in the upper portion of the main body and transmit a detection signal to the control unit.
또한 본 발명의 빙설 제거로봇은 상기 본체에 회전 가능하게 설치되어 본체에 대해 회전하면서 본체 주변의 환경을 촬영하여 상기 제어부로 전송하는 카메라와, 상기 카메라를 회전시키는 카메라 회동유닛을 더 포함할 수 있다. In addition, the ice and snow removal robot of the present invention may further include a camera that is rotatably installed on the main body and shoots the environment around the main body while being rotated relative to the main body and transmits it to the control unit and a camera rotation unit that rotates the camera. .
본 발명의 한 실시형태에 따르면, 상기 빙설제거부는 본체의 일 측면 또는 양 측면에서 송전선로가 관통하도록 설치되는 원추형의 허브와, 상기 허브의 외면에 원주방향을 따라 간격을 두고 배열되는 복수의 블레이드를 구비한 제설부재를 포함한다. According to one embodiment of the present invention, the ice and snow removal unit is a conical hub that is installed to transmit power lines from one side or both sides of the main body, and a plurality of blades arranged at intervals along the circumferential direction on the outer surface of the hub It includes a snow removing member having a.
또한 상기 빙설제거부는 상기 제설부재를 본체 및 송전선로에 대해 회전시키는 허브회전유닛을 더 포함할 수 있다. In addition, the ice and snow removal unit may further include a hub rotating unit for rotating the snow removing member relative to the main body and the transmission line.
상기 허브회전유닛은, 상기 본체에 설치되어 상기 제어부로부터 인가되는 신호에 의해 회전 동작하는 허브회동모터와, 상기 허브회동모터의 회전력을 상기 제설부재의 허브에 전달하는 동력전달부재를 포함할 수 있다. The hub rotation unit may include a hub rotation motor installed in the main body to rotate by a signal applied from the control unit, and a power transmission member transmitting the rotational force of the hub rotation motor to the hub of the snow removal member. .
상기 허브와 본체는 송전선로의 일부분이 수용되는 부분과 송전선로의 나머지 일부분이 수용되는 부분으로 분할 가능하게 구성될 수 있다. The hub and the main body may be configured to be divided into a portion in which a portion of the transmission line is accommodated and a portion in which the remaining portion of the transmission line is accommodated.
상기 구동부는, 상기 본체에 송전선로와 직교하는 구동축을 중심으로 회전 가능하게 설치되고 외면이 송전선로의 외면에 접촉하여 송전선로를 따라 구름 운동하는 구동휠과, 상기 제어부로부터 인가되는 신호에 의해 회전 작동하여 상기 구동휠을 회전시키는 구동모터, 상기 본체에 송전선로와 직교하는 축을 중심으로 회전 가능하게 설치되고 외면이 송전선로의 외면에 밀착되면서 구름운동하며 지지력을 제공하는 적어도 1개 이상의 서포트휠을 포함할 수 있다. The driving unit is rotatably installed on the main body to be rotatable around a driving shaft orthogonal to the transmission line, and the outer surface contacts the outer surface of the transmission line and performs rolling motion along the transmission line and a signal applied from the control unit. A driving motor that rotates the driving wheel by operating, and is provided rotatably around an axis orthogonal to the transmission line, and has at least one support wheel that provides rolling and supports while rolling on the outer surface in close contact with the outer surface of the transmission line. It can contain.
상기 제어부는 외부의 제어장치와 무선통신을 수행하는 무선통신모듈을 포함할 수 있다. The control unit may include a wireless communication module that performs wireless communication with an external control device.
본 발명의 빙설 제거로봇은, 상기 빙설제거부에 설치되어 제어부로부터 인가되는 신호에 의해 발열하는 전열히터를 더 포함할 수 있다. The ice and snow removal robot of the present invention may further include an electric heater that is installed in the ice and snow removal unit and generates heat by a signal applied from a control unit.
본 발명의 다른 한 형태에 따른 빙설 제거로봇은, 송전선로를 따라 이동 가능하게 설치되는 본체; 상기 본체에 송전선로와 직교하는 구동축을 중심으로 회전 가능하게 설치되고 외면이 송전선로의 외면에 접촉하여 송전선로를 따라 구름 운동하는 구동휠; 제어부로부터 인가되는 신호에 의해 회전 작동하여 상기 구동휠을 회전시키는 구동모터; 상기 본체에 송전선로와 직교하는 축을 중심으로 회전 가능하게 설치되고 외면이 송전선로의 외면에 밀착되면서 구름운동하며 지지력을 제공하는 적어도 1개 이상의 서포트휠; 상기 본체의 일 측면 또는 양 측면에서 송전선로가 관통하도록 설치되며 본체에 대해 회전 가능하게 설치되는 원추형의 허브와 상기 허브의 외면에 원주방향을 따라 간격을 두고 배열되어 송전선로에 쌓인 빙설을 제거하는 복수의 블레이드를 구비한 제설부재와, 상기 본체에 설치되어 상기 제어부로부터 인가되는 신호에 의해 회전 동작하는 허브회동모터와, 상기 허브회동모터의 회전력을 상기 제설부재의 허브에 전달하는 동력전달부재를 포함하는 빙설제거부; 상기 구동모터와 허브회동모터의 작동을 제어하는 제어부; 상기 본체의 상부에 설치되어 본체의 상부에 쌓이는 빙설의 적설량을 감지하고 감지 신호를 상기 제어부로 전송하는 적설량 센서; 상기 본체에 회전 가능하게 설치되어 본체에 대해 회전하면서 본체 주변의 환경을 촬영하여 상기 제어부로 전송하는 카메라; 및, 상기 카메라를 회전시키는 카메라 회동유닛;을 포함하여 구성될 수 있다. Ice and snow removal robot according to another aspect of the present invention, the main body is installed to be movable along the transmission line; A driving wheel rotatably installed around the driving shaft orthogonal to the transmission line and the outer surface contacting the outer surface of the transmission line and rolling in motion along the transmission line; A driving motor rotating by the signal applied from the control unit to rotate the driving wheel; At least one support wheel that is rotatably installed around an axis orthogonal to the transmission line in the main body, and the outer surface is in close contact with the outer surface of the transmission line to provide rolling support while rolling; The conical hub is installed to penetrate the transmission line from one side or both sides of the main body and is rotatably installed with respect to the main body, and arranged at intervals along the circumferential direction on the outer surface of the hub to remove ice and snow accumulated on the transmission line. A snow removal member having a plurality of blades, a hub rotation motor installed in the main body and rotating by a signal applied from the control unit, and a power transmission member transmitting the rotational force of the hub rotation motor to the hub of the snow removal member Ice and snow removal unit comprising; A control unit for controlling the operation of the drive motor and the hub rotation motor; A snowfall sensor installed on an upper portion of the main body to detect the amount of snowfall accumulated in the upper portion of the body and transmit a detection signal to the control unit; A camera that is rotatably installed on the main body and rotates relative to the main body to photograph an environment around the main body and transmit the image to the control unit; And a camera rotating unit that rotates the camera.
본 발명에 따르면, 빙설 제거로봇이 이미 설치되어 있는 송전선로에 장착되어 송전선로를 따라 이동하면서 허브의 블레이드로 빙설을 제거할 수 있다. 따라서 송전선로에 쌓인 빙설을 안전하고 효과적으로 제거할 수 있다.According to the present invention, the ice and snow removal robot is mounted on a power transmission line that is already installed and can move along the power transmission line to remove ice and snow with a blade of a hub. Therefore, it is possible to safely and effectively remove ice and snow accumulated on the transmission line.
또한 송전선로의 주변 환경과 적설량에 따라 원격 통신으로 빙설 제거로봇을 작동시킬 수 있으므로 빙설 제거가 필요한 상황에서 효율적으로 빙설 제거 작업을 수행할 수 있다.In addition, since the ice removal robot can be operated by remote communication according to the surrounding environment of the transmission line and the amount of snow, it is possible to efficiently perform ice removal in a situation where ice removal is required.
그리고 카메라를 이용하여 송전선로 주변 환경을 촬영하여 주변 상황을 검색하는 환경 검색 로봇의 기능도 수행할 수 있다. In addition, it is possible to perform a function of an environment search robot that searches for surrounding conditions by photographing the surrounding environment using a camera.
도 1은 본 발명의 일 실시예에 따른 송전선로의 빙설 제거로봇의 내부 구성을 나타낸 측면도이다.
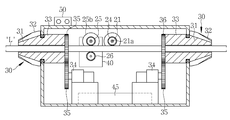
도 2는 도 1에 도시된 빙설 제거로봇의 단면도이다.
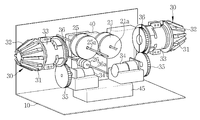
도 3은 도 1에 도시된 빙설 제거로봇의 내부 구성을 나타낸 사시도이다.
도 4는 도 1에 도시된 빙설 제거로봇의 일부 구성을 제거하고 나타낸 사시도이다.
도 5는 도 1에 도시된 빙설 제거로봇의 다른 일부 구성을 제거하고 나타낸 사시도이다.
도 6은 도 1에 도시된 빙설 제거로봇의 작동을 위한 제어 구성을 나타낸 블록도이다.1 is a side view showing an internal configuration of a snow and ice removal robot of a transmission line according to an embodiment of the present invention.
FIG. 2 is a cross-sectional view of the ice and snow removal robot illustrated in FIG. 1.
3 is a perspective view showing the internal configuration of the ice and snow removal robot shown in FIG.
FIG. 4 is a perspective view illustrating a part of the ice and snow removal robot illustrated in FIG. 1 removed.
FIG. 5 is a perspective view of the ice removal robot illustrated in FIG. 1 with some other components removed.
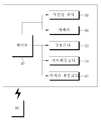
FIG. 6 is a block diagram showing a control configuration for operation of the ice and snow removal robot illustrated in FIG. 1.
본 명세서에 기재된 실시예와 도면에 도시된 구성은 개시된 발명의 바람직한 일 예에 불과할 뿐이며, 본 출원의 출원시점에 있어서 본 명세서의 실시예와 도면을 대체할 수 있는 다양한 변형 예들이 있을 수 있다.The configuration shown in the embodiments and drawings described in this specification is only a preferred example of the disclosed invention, and at the time of filing of the present application, there may be various modifications that can replace the embodiments and drawings of the present specification.
이하에서는 첨부된 도면을 참조하여 송전선로의 빙설 제거로봇을 후술된 실시예들에 따라 구체적으로 설명하도록 한다. 도면에서 동일한 부호는 동일한 구성 요소를 나타낸다. Hereinafter, the ice and snow removal robot of the transmission line will be described in detail with reference to embodiments described below with reference to the accompanying drawings. The same reference numerals in the drawings indicate the same components.
도 1 내지 도 6은 본 발명의 일 실시예에 따른 송전선로의 빙설 제거로봇을 나타낸 것으로, 송전선로의 빙설 제거로봇은 송전선로(L)를 따라 이동 가능하게 설치되는 본체(10), 상기 본체(10)에 송전선로(L)와 밀착되게 설치되어 상기 본체(10)가 송전선로(L)를 따라 이동하도록 동력을 제공하는 구동부, 상기 본체(10)에 설치되어 본체(10)가 구동부에 의해 이동할 때 상기 송전선로에 쌓인 빙설과 접촉하면서 빙설을 제거하는 빙설제거부, 상기 구동부의 작동을 제어하는 제어부(40), 상기 본체(10)의 상부에 설치되어 본체(10)의 상부에 쌓이는 빙설의 적설량을 감지하여 감지 신호를 상기 제어부(40)로 전송하는 적설량 센서(50), 상기 본체(10)의 상부에 회전 가능하게 설치되어 본체(10)에 대해 회전하면서 본체(10) 주변의 환경을 촬영하여 상기 제어부(40)로 전송하는 카메라(60)와, 상기 카메라(60)를 회전시키는 카메라 회동유닛을 포함한다. 1 to 6 show the ice and snow removal robot of the transmission line according to an embodiment of the present invention, the ice and snow removal robot of the transmission line is a
상기 본체(10)는 대략 직육면체의 함체 형태를 가지며, 송전선로(L)를 수용할 수 있도록 상부면이 개방된 함체 형태의 하부 본체(10a)와, 하부면이 개방된 함체 형태로 되어 상기 하부 본체(10a)의 상부에 결합되는 상부 본체(10b)로 분할되게 구성된다. 상기 상부 본체(10b)는 일측이 하부 본체(10a)에 힌지(미도시)로 연결되어 하부 본체(10a)에 대해 상하로 회전하면서 하부 본체(10a)에 결합될 수 있다. The
상기 구동부는 빙설 제거로봇 전체를 송전선로를 따라 이동하도록 하는 것으로, 이 실시예에서 구동부는 상기 본체(10)에 송전선로(L)와 직교하는 구동축(21a)을 중심으로 회전 가능하게 설치되고 외면이 송전선로(L)의 외면에 접촉하여 송전선로(L)를 따라 구름 운동하는 구동휠(21)과, 상기 제어부(40)로부터 인가되는 신호에 의해 회전 작동하여 상기 구동휠을 회전시키는 구동모터(22), 상기 본체(10)에 송전선로(L)와 직교하는 축을 중심으로 회전 가능하게 설치되고 외면이 송전선로(L)의 외면에 밀착되면서 구름운동하며 지지력을 제공하는 복수의 서포트휠(25, 26)을 포함한다. The driving unit is to move the entire ice removal robot along the transmission line. In this embodiment, the driving unit is rotatably installed on the
상기 구동휠(21)의 외면은 송전선로(L)의 외면과 밀착되면서 회전하여 구름 운동하게 되고, 이에 따라 본체(10)가 송전선로(L)의 길이방향을 따라 이동하게 된다. 상기 구동휠(21)의 외면과 송전선로(L) 간의 마찰력을 증대시키기 위하여 구동휠(21)의 외면에 고무와 같이 마찰력이 큰 수지로 된 마찰재(24)가 설치될 수 있다. The outer surface of the
상기 구동모터(22)는 구동휠(21)의 구동축(21a)과 직결되어 구동축(21a)에 회전력을 전달함으로써 구동휠(21)을 회전시킨다. 물론 이와 다르게 구동모터(22)가 기어나 벨트 등의 동력전달부재를 통해 구동축(21a)에 연결되어 회전력을 전달할 수도 있다. 상기 구동모터(22)는 본체(10)의 일측면에 고정되는 모터케이스(23) 내부에 설치될 수 있다. 상기 구동모터(22)는 제어부(40)와 전기적으로 연결되어 제어부(40)로부터 신호를 인가받아 작동한다. The
서포트휠(25, 26)은 구동휠(21)에 의한 본체(10)의 이동시 송전선로(L)의 외면에 밀착되어 회전함으로써 안정적인 이동이 이루어질 수 있도록 한다. 상기 서포트휠(25, 26)은 송전선로(L)의 상부와 하부에서 지지력을 제공할 수 있도록 2개가 상하로 이격되게 배치될 수 있다. 이 때 상기 2개의 서포트휠(25, 26) 중 상부에 배치되는 서포트휠(25)의 양면에는 송전선로(L)의 측면부를 수용하면서 더욱 안정적인 지지력을 제공할 수 있도록 측면지지판(25b)이 마련될 수 있다.The
상기 빙설제거부는 본체(10)의 양 측면 외측에서 송전선로(L)가 관통하도록 설치되는 원추형의 허브(31)와 상기 허브(31)의 외면에 원주방향을 따라 간격을 두고 배열되는 복수의 블레이드(32)를 포함하는 제설부재(30), 상기 제설부재(30)를 본체 및 송전선로에 대해 회전시키는 허브회전유닛을 포함한다. 상기 허브회전유닛은, 상기 본체(10)에 설치되어 상기 제어부(40)로부터 인가되는 신호에 의해 회전 동작하는 허브회동모터(34)와, 상기 허브회동모터(34)의 회전력을 상기 허브(31)에 전달하는 동력전달부재를 포함한다. The ice and snow removal unit is a plurality of blades arranged at intervals along the circumferential direction on the outer surface of the
상기 제설부재(30)의 허브(31)는 중공의 원추형으로 되어 중심의 중공을 통해 송전선로(L)가 관통한다. 상기 허브(31)의 중공 내측으로 송전선로(L)를 삽입할 수 있도록 하기 위하여 허브(31)는 2개의 반원추형으로 이루어진 부분으로 분할되게 만들어진다. 상기 허브(31)는 본체(10)에 대해 회전이 가능하게 설치되어 본체(10)가 송전선로(L)를 따라 이동할 때 허브(31)가 회전하면서 그 외면의 블레이드(32)가 송전선로(L)에 쌓인 빙설을 제거하게 된다. The
상기 허브(31)의 끝단부에는 본체(10)의 내측으로 입입되는 중공의 원통형으로 된 회전부재(33)가 설치된다. 상기 회전부재(33)의 끝단에는 허브회동모터(34)로부터 동력을 전달받기 위한 종동기어(36)가 설치된다. The
상기 블레이드(32)는 허브(31)의 외면에 돌출되게 형성되며, 복수개가 허브(31)의 원주방향을 따라 일정 간격으로 배열된다. 상기 블레이드(32)는 송전선로(L)에 쌓인 빙설을 효과적으로 제거할 수 있도록 허브(31)의 선단부로 갈수록 뾰족해지는 삼각형으로 이루어지는 것이 바람직하다. The
도면에 도시하지는 않았으나, 제설부재(30)가 송전선로(L)의 빙설을 제거할 때 빙설 제거 효율을 더욱 높이기 위하여 상기 제설부재(30)의 허브(31)에 상기 제어부(40)로부터 인가되는 신호에 의해 발열하는 전열히터를 추가로 설치할 수 있다. Although not shown in the drawing, when the
상기 허브(31)를 회전시키기 위한 허브회전유닛은 본체(10)의 내부 양측에 설치되는 2개의 허브회동모터(34)와, 상기 각각의 허브회동모터(34)의 회전력을 허브(31)의 끝단부로 전달하는 동력전달부재를 포함한다. 상기 동력전달부재는 허브회동모터(34)의 축에 연결되어 회전하는 구동기어(35)와, 상기 회전부재(33)의 끝단부에 설치되어 상기 구동기어(35)와 치합되는 종동기어(36)를 포함한다. 따라서 허브회동모터(34)에 의해 구동기어(35)가 회전하면 종동기어(36)가 구동기어(35)의 반대방향으로 회전하면서 허브(31) 및 블레이드(32)가 회전하여 빙설을 제거할 수 있게 된다. The hub rotating unit for rotating the
상기 적설량 센서(50)는 본체(10)의 상부면에 설치되어 본체(10)의 상부면에 쌓인 빙설의 퇴적량(적설량)을 실시간으로 측정하고 측정된 신호를 제어부(40)로 전송한다. 상기 적설량 센서(50)는 공지의 레이저 센서 등을 적용할 수 있다. The
또한 본 발명의 빙설 제거장치는 송전선로 주변의 환경을 촬영하여 외부의 관제센터의 PC로 전송하기 위한 카메라(60)를 구비한다. 상기 카메라(60)는 본체(10)의 상부면에 360도로 회전 가능하게 설치되어 카메라 회동유닛에 의해 시계방향 또는 반시계방향으로 회전하면서 주변 환경을 촬영하여 제어부(40)로 전송한다. 상기 카메라 회동유닛은 상기 카메라(60)의 축에 직결되거나 기어 등의 동력전달부재를 매개로 연결되어 회전력을 전달하는 카메라 회동모터(61)로 구성될 수 있다. In addition, the ice and snow removal apparatus of the present invention includes a
상기 제어부(40)는 상기 적설량 센서(50) 및 카메라(60)로부터 신호를 전송받아 처리하며, 상기 구동모터(22)와 허브회동모터(34), 카메라 회동모터(61)의 작동을 제어할 수 있도록 구성된다. 또한 제어부(40)는 외부의 관제센터와의 무선통신을 위한 무선통신모듈(미도시)을 구비할 수 있다. The
상기 본체(10) 내에는 상기 제어부(40)와 모터(22, 34, 61)의 작동을 위한 전원을 공급하기 위한 배터리(45)가 설치된다. 또한 본 발명의 빙설 제거장치를 설치한 후 상시적으로 전원을 공급할 수 있도록 하기 위하여 본체(10)에 태양광 에너지를 이용하여 전력을 생산하는 태양광패널과 생산된 전력을 충전하는 충전기, 또는 풍력발전기와 충전기, 압전소자와 충전기 등을 포함하는 에너지 하베스트 장치를 장착하여 오랜 시간이 경과하더라도 배터리의 교체 없이 안정적으로 전원을 공급할 수도 있을 것이다. In the
이하 상기한 구성으로 이루어진 빙설 제거장치의 작동에 대해 설명하면 다음과 같다. Hereinafter, the operation of the ice and snow removal device having the above-described configuration will be described.
먼저 빙설 제거장치를 송전선로(L)에 조립하여 설치한다. 이 때 상부 본체(10b)를 하부 본체(10a)에 대해 회전시켜 벌림과 동시에 허브(31)를 벌린 후 벌어진 공간 내측으로 송전선로(L)를 삽입하여 구동휠(21) 및 서포트휠(25, 26)의 외면이 송전선로(L)와 접촉하도록 함과 동시에 허브(31)의 중공 내측으로 삽입되도록 한 후 다시 상부 본체(10b)와 허브(31)를 닫아서 빙설 제거장치를 송전선로(L)에 설치한다. First, the ice removal device is assembled and installed on the transmission line (L). At this time, the
이 후 본체(10)의 상부면에 눈이 내리거나 얼음이 얼어서 일정량 이상 쌓이게 되면 적설량 센서(50)가 이를 감지하여 제어부(40)로 감지 신호를 전송한다. 상기 제어부(40)는 적설량이 일정량 이상(예를 들어 5㎜ 이상)이 되면, 자체적으로 구동모터(22) 및/또는 허브회동모터(34)에 신호를 인가하거나, 혹은 외부의 관제센터의 PC로 무선통신으로 적설량 정보를 전달하여 PC로부터 구동모터(22) 및/또는 허브회동모터(34)의 작동을 위한 신호를 전달받는다.Thereafter, when snow or ice freezes on the upper surface of the
상기 제어부(40)로부터 구동모터(22)에 신호가 전송되어 구동모터(22)가 어느 한 방향으로 작동하면, 구동모터(22)의 동력이 구동축(21a)을 통해 구동휠(21)로 전달되어 구동휠(21)이 회전하게 되고, 이에 따라 구동휠(21)이 송전선로(L)를 따라 구름 운동하여 본체(10)가 송전선로(L)의 길이방향을 따라 어느 한 쪽으로 이동하게 된다. When a signal is transmitted from the
이와 동시에 제어부(40)로부터 허브회동모터(34)에 신호가 인가되어 허브회동모터(34)가 일방향으로 회전하게 되면, 구동기어(35)를 통해 회전부재(33)의 종동기어(36)로 회전력이 전달되어 허브(31)가 일방향으로 회전하게 된다. 이에 따라 본체(10)의 진행방향 전단부에 위치한 허브(31) 및 블레이드(32)가 송전선로(L)에 쌓인 빙설을 밀어내면서 제거하게 된다. At the same time, when a signal is applied from the
한편 상기 카메라(60)는 제어부(40)에 의해 카메라 회동모터(61)로 전송되는 신호에 의해 주기적으로 또는 관제센터의 PC로부터 작동 신호가 전송될 때 360도로 회전하면서 주변 환경을 촬영하여 주변 환경 정보를 획득하고, 제어부(40)는 획득된 주변 환경 정보를 무선통신을 통해 관제센터의 PC로 전송한다. 이를 통해 구동모터(22)와 허브회동모터(34)는 제어부(40)와 연결된 무선통신모듈을 통해 필요시 원격으로 직접 제어가 가능하다. 관제센터는 전송된 환경정보를 보고 빙설 제거 등이 필요할 경우 PC를 통해 상기 제어부(40)로 제어 신호를 송출하여 제어부(40)가 구동모터(22) 및/또는 허브회동모터(34)를 작동시킨다. On the other hand, the
이와 같이 본 발명의 빙설 제거로봇은 송전선로(L)에 장착되어 송전선로(L)를 따라 이동하면서 허브(31)의 블레이드(32)로 빙설을 제거할 수 있다. 따라서 송전선로(L)에 쌓인 빙설을 효과적으로 제거할 수 있다.As described above, the ice and snow removal robot of the present invention is mounted on the power transmission line (L) and moves along the power transmission line (L) to remove ice and snow with the blade (32) of the hub (31). Therefore, ice and snow accumulated on the transmission line L can be effectively removed.
또한 송전선로(L)의 주변 환경과 적설량에 따라 원격 통신으로 빙설 제거로봇을 작동시킬 수 있으므로 빙설 제거가 필요한 상황에서 즉각적으로 빙설 제거 작업을 수행할 수 있다.In addition, since the snow removal robot can be operated by remote communication according to the surrounding environment and the amount of snowfall in the transmission line L, it is possible to immediately perform the snow and snow removal operation in a situation where it is necessary to remove the snow and ice.
이상에서 본 발명은 실시예를 참조하여 상세히 설명되었으나, 본 발명이 속하는 기술분야에서 통상의 지식을 가진 자라면 상기에서 설명된 기술적 사상을 벗어나지 않는 범위 내에서 여러 가지 치환, 부가 및 변형이 가능할 것임은 당연하며, 이와 같은 변형된 실시 형태들 역시 아래에 첨부한 특허청구범위에 의하여 정하여지는 본 발명의 보호 범위에 속하는 것으로 이해되어야 할 것이다.In the above, the present invention has been described in detail with reference to examples, but those skilled in the art to which the present invention pertains will be capable of various substitutions, additions, and modifications without departing from the technical spirit described above. Of course, such modified embodiments should also be understood as belonging to the protection scope of the present invention as defined by the appended claims.
L : 송전선로
10 : 본체
21 : 구동휠
21a : 구동축
22 : 구동모터
23 : 모터케이스
24 : 마찰재
30 : 제설부재
31 : 허브
32 : 블레이드
33 : 회전부재
34 : 허브회동모터
35 : 구동기어
36 : 종동기어
40 : 제어부
45 : 배터리
50 : 적설량 센서
60 : 카메라
61 : 카메라 회동모터L: Transmission line 10: Main body
21:
22: drive motor 23: motor case
24: friction material 30: snow removal member
31: hub 32: blade
33: rotating member 34: hub rotation motor
35: drive gear 36: driven gear
40: control unit 45: battery
50: snowfall sensor 60: camera
61: camera rotation motor
Claims (12)
상기 본체에 송전선로와 밀착되게 설치되어 상기 본체가 송전선로를 따라 이동하도록 동력을 제공하는 구동부;
상기 본체에 설치되어 본체가 구동부에 의해 이동할 때 상기 송전선로에 쌓인 빙설과 접촉하면서 빙설을 제거하는 빙설제거부; 및,
상기 구동부의 작동을 제어하는 제어부;
를 포함하는 송전선로의 빙설 제거로봇.The main body is installed to be movable along the transmission line;
A driving unit installed in close contact with the transmission line in the main body to provide power to move the main body along the transmission line;
An ice and snow removal unit installed on the main body to remove ice and snow while contacting ice and ice accumulated on the power transmission line when the main body is moved by the driving unit; And,
A control unit controlling operation of the driving unit;
Ice removal robot of the transmission line comprising a.
상기 본체에 송전선로와 직교하는 구동축을 중심으로 회전 가능하게 설치되고 외면이 송전선로의 외면에 접촉하여 송전선로를 따라 구름 운동하는 구동휠;
제어부로부터 인가되는 신호에 의해 회전 작동하여 상기 구동휠을 회전시키는 구동모터;
상기 본체에 송전선로와 직교하는 축을 중심으로 회전 가능하게 설치되고 외면이 송전선로의 외면에 밀착되면서 구름운동하며 지지력을 제공하는 적어도 1개 이상의 서포트휠;
상기 본체의 일 측면 또는 양 측면에서 송전선로가 관통하도록 설치되며 본체에 대해 회전 가능하게 설치되는 원추형의 허브와 상기 허브의 외면에 원주방향을 따라 간격을 두고 배열되어 송전선로에 쌓인 빙설을 제거하는 복수의 블레이드를 구비한 제설부재와, 상기 본체에 설치되어 상기 제어부로부터 인가되는 신호에 의해 회전 동작하는 허브회동모터와, 상기 허브회동모터의 회전력을 상기 제설부재의 허브에 전달하는 동력전달부재를 포함하는 빙설제거부;
상기 구동모터와 허브회동모터의 작동을 제어하는 제어부;
상기 본체의 상부에 설치되어 본체의 상부에 쌓이는 빙설의 적설량을 감지하고 감지 신호를 상기 제어부로 전송하는 적설량 센서;
상기 본체에 회전 가능하게 설치되어 본체에 대해 회전하면서 본체 주변의 환경을 촬영하여 상기 제어부로 전송하는 카메라; 및,
상기 카메라를 회전시키는 카메라 회동유닛;
을 포함하는 송전선로의 빙설 제거로봇.
The main body is installed to be movable along the transmission line;
A drive wheel rotatably installed around the drive shaft orthogonal to the transmission line and the outer surface contacting the outer surface of the transmission line and rolling in motion along the transmission line;
A driving motor rotating by the signal applied from the control unit to rotate the driving wheel;
At least one support wheel that is rotatably installed around an axis orthogonal to the transmission line and that the outer surface is in close contact with the outer surface of the transmission line and performs rolling motion and provides support;
The conical hub is installed to penetrate the transmission line from one side or both sides of the main body and is rotatably installed with respect to the main body, and arranged at intervals along the circumferential direction on the outer surface of the hub to remove ice and snow accumulated on the transmission line. A snow removal member having a plurality of blades, a hub rotation motor installed on the main body and rotating by a signal applied from the control unit, and a power transmission member transmitting the rotational force of the hub rotation motor to the hub of the snow removal member Ice and snow removal unit comprising;
A control unit for controlling the operation of the drive motor and the hub rotation motor;
A snowfall sensor installed on an upper portion of the main body to detect the amount of snowfall accumulated in the upper portion of the body and transmit a detection signal to the control unit;
A camera which is rotatably installed on the main body and rotates relative to the main body to photograph an environment around the main body and transmit it to the control unit; And,
A camera rotation unit for rotating the camera;
Ice removal robot of the transmission line comprising a.
Priority Applications (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| KR1020180148811A KR102231749B1 (en) | 2018-11-27 | 2018-11-27 | Robot for Removing Ice And Snow on Transmission Line |
Applications Claiming Priority (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| KR1020180148811A KR102231749B1 (en) | 2018-11-27 | 2018-11-27 | Robot for Removing Ice And Snow on Transmission Line |
Publications (2)
| Publication Number | Publication Date |
|---|---|
| KR20200062880A true KR20200062880A (en) | 2020-06-04 |
| KR102231749B1 KR102231749B1 (en) | 2021-03-24 |
Family
ID=71080761
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| KR1020180148811A Active KR102231749B1 (en) | 2018-11-27 | 2018-11-27 | Robot for Removing Ice And Snow on Transmission Line |
Country Status (1)
| Country | Link |
|---|---|
| KR (1) | KR102231749B1 (en) |
Cited By (23)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN112134241A (en) * | 2020-09-28 | 2020-12-25 | 李奇 | Composite deicing and dewatering tool for high voltage transmission line deicing robot |
| CN112332355A (en) * | 2020-10-19 | 2021-02-05 | 秦金凤 | Portable deicer for high-voltage line |
| CN112474616A (en) * | 2020-10-28 | 2021-03-12 | 中国科学院深圳先进技术研究院 | Deicing robot |
| CN112564009A (en) * | 2020-12-01 | 2021-03-26 | 青岛凯顺兴设备工程有限公司 | Power transmission line snow and ice removing device for electric power overhaul |
| CN113036699A (en) * | 2021-03-02 | 2021-06-25 | 郑州工业应用技术学院 | Automatic deicing system of electric power |
| CN113131427A (en) * | 2021-04-20 | 2021-07-16 | 国网山东省电力公司乳山市供电公司 | Cable surface ice-removing device |
| CN113471919A (en) * | 2021-07-09 | 2021-10-01 | 郑州理工职业学院 | Automatic control deicing robot for power transmission line |
| CN113725798A (en) * | 2021-08-31 | 2021-11-30 | 国网河南省电力公司社旗县供电公司 | Cable deicing device |
| CN114123085A (en) * | 2021-12-24 | 2022-03-01 | 广东电网有限责任公司 | High altitude cable ice and snow remove device |
| CN114301021A (en) * | 2021-11-30 | 2022-04-08 | 长江大学工程技术学院 | Deicer for high-voltage transmission line |
| CN114336486A (en) * | 2021-12-02 | 2022-04-12 | 国网江苏省电力有限公司盐城供电分公司 | Snow removal control system for unmanned aerial vehicle |
| CN114744542A (en) * | 2022-03-26 | 2022-07-12 | 程兆鹏 | Power grid maintenance robot and use method thereof |
| CN114884002A (en) * | 2022-06-07 | 2022-08-09 | 三峡大学 | A transmission line icing remove device for on electric power electrical engineering |
| CN115833012A (en) * | 2022-10-27 | 2023-03-21 | 国网山西省电力公司阳泉供电公司 | Transmission line induction type automatic snow-removing shockproof hammer and transmission line system |
| CN116231571A (en) * | 2023-03-27 | 2023-06-06 | 国网安徽省电力有限公司全椒县供电公司 | A power grid wiring device |
| CN116632720A (en) * | 2023-07-18 | 2023-08-22 | 国网安徽省电力有限公司巢湖市供电公司 | An intelligent inspection device for high-voltage lines |
| CN116914677A (en) * | 2023-09-12 | 2023-10-20 | 长春晟德科技有限公司 | Icing cleaning device for surface of power transmission wire |
| CN118763589A (en) * | 2024-09-06 | 2024-10-11 | 国机传感科技有限公司 | Cable ice removal device |
| CN118825905A (en) * | 2024-09-20 | 2024-10-22 | 河南海平线科技有限公司 | Rail-type electric power automatic inspection robot based on ray technology and operation method |
| CN119297910A (en) * | 2024-12-13 | 2025-01-10 | 武汉雷特科技有限公司 | A wire deicing device based on thermal ice melting |
| CN120073548A (en) * | 2025-03-13 | 2025-05-30 | 南京冉小星科技有限公司 | Power network transmission line cable detection device and system thereof |
| CN120090113A (en) * | 2025-04-30 | 2025-06-03 | 国网河南省电力公司新乡供电公司 | A deicing device for a power transmission line |
| CN120527831A (en) * | 2025-07-23 | 2025-08-22 | 山西丹旭泰电力科技有限公司 | Deicing device for power line |
Citations (6)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JPH06194460A (en) * | 1992-12-24 | 1994-07-15 | Hitachi Cable Ltd | Transmission line ice accretion detector |
| KR101554983B1 (en) | 2013-11-12 | 2015-09-23 | 한국전기연구원 | manufacturing method of aluminium power line preventing an ice coating |
| KR20150125182A (en) * | 2014-04-30 | 2015-11-09 | 한전케이피에스 주식회사 | Ice and snow removal instrument for power line |
| KR101599267B1 (en) | 2013-09-05 | 2016-03-04 | 한국전력공사 | Device for removing ice and snow of transmission line |
| JP2016054582A (en) * | 2014-09-03 | 2016-04-14 | 株式会社ジェイ・パワーシステムズ | Electric wire snow removal device, electric wire snow removal device manufacturing method, and electric wire snow removal method |
| KR20180032073A (en) | 2016-09-21 | 2018-03-29 | 한국전력공사 | Hard stuck ice and snow-preventing device |
-
2018
- 2018-11-27 KR KR1020180148811A patent/KR102231749B1/en active Active
Patent Citations (6)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JPH06194460A (en) * | 1992-12-24 | 1994-07-15 | Hitachi Cable Ltd | Transmission line ice accretion detector |
| KR101599267B1 (en) | 2013-09-05 | 2016-03-04 | 한국전력공사 | Device for removing ice and snow of transmission line |
| KR101554983B1 (en) | 2013-11-12 | 2015-09-23 | 한국전기연구원 | manufacturing method of aluminium power line preventing an ice coating |
| KR20150125182A (en) * | 2014-04-30 | 2015-11-09 | 한전케이피에스 주식회사 | Ice and snow removal instrument for power line |
| JP2016054582A (en) * | 2014-09-03 | 2016-04-14 | 株式会社ジェイ・パワーシステムズ | Electric wire snow removal device, electric wire snow removal device manufacturing method, and electric wire snow removal method |
| KR20180032073A (en) | 2016-09-21 | 2018-03-29 | 한국전력공사 | Hard stuck ice and snow-preventing device |
Cited By (34)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN112134241A (en) * | 2020-09-28 | 2020-12-25 | 李奇 | Composite deicing and dewatering tool for high voltage transmission line deicing robot |
| CN112332355B (en) * | 2020-10-19 | 2022-06-24 | 南京灵雀智能制造有限公司 | Portable deicer for high-voltage line |
| CN112332355A (en) * | 2020-10-19 | 2021-02-05 | 秦金凤 | Portable deicer for high-voltage line |
| CN112474616A (en) * | 2020-10-28 | 2021-03-12 | 中国科学院深圳先进技术研究院 | Deicing robot |
| CN112564009A (en) * | 2020-12-01 | 2021-03-26 | 青岛凯顺兴设备工程有限公司 | Power transmission line snow and ice removing device for electric power overhaul |
| CN112564009B (en) * | 2020-12-01 | 2022-06-28 | 崇瑞飞科(山东)电力科技有限公司 | Power maintenance is with power transmission line defroster that clears snow |
| CN113036699A (en) * | 2021-03-02 | 2021-06-25 | 郑州工业应用技术学院 | Automatic deicing system of electric power |
| CN113036699B (en) * | 2021-03-02 | 2022-07-12 | 郑州工业应用技术学院 | Automatic deicing system of electric power |
| CN113131427A (en) * | 2021-04-20 | 2021-07-16 | 国网山东省电力公司乳山市供电公司 | Cable surface ice-removing device |
| CN113131427B (en) * | 2021-04-20 | 2022-09-13 | 国网山东省电力公司乳山市供电公司 | Cable surface ice-removing device |
| CN113471919B (en) * | 2021-07-09 | 2022-06-03 | 郑州理工职业学院 | Automatic control deicing robot for power transmission line |
| CN113471919A (en) * | 2021-07-09 | 2021-10-01 | 郑州理工职业学院 | Automatic control deicing robot for power transmission line |
| CN113725798A (en) * | 2021-08-31 | 2021-11-30 | 国网河南省电力公司社旗县供电公司 | Cable deicing device |
| CN113725798B (en) * | 2021-08-31 | 2023-08-18 | 国网河南省电力公司社旗县供电公司 | Cable deicing device |
| CN114301021A (en) * | 2021-11-30 | 2022-04-08 | 长江大学工程技术学院 | Deicer for high-voltage transmission line |
| CN114336486A (en) * | 2021-12-02 | 2022-04-12 | 国网江苏省电力有限公司盐城供电分公司 | Snow removal control system for unmanned aerial vehicle |
| CN114336486B (en) * | 2021-12-02 | 2023-09-26 | 国网江苏省电力有限公司盐城供电分公司 | A kind of UAV snow removal control system |
| CN114123085A (en) * | 2021-12-24 | 2022-03-01 | 广东电网有限责任公司 | High altitude cable ice and snow remove device |
| CN114123085B (en) * | 2021-12-24 | 2024-07-02 | 广东电网有限责任公司 | High-altitude cable ice and snow removing device |
| CN114744542A (en) * | 2022-03-26 | 2022-07-12 | 程兆鹏 | Power grid maintenance robot and use method thereof |
| CN114884002A (en) * | 2022-06-07 | 2022-08-09 | 三峡大学 | A transmission line icing remove device for on electric power electrical engineering |
| CN115833012A (en) * | 2022-10-27 | 2023-03-21 | 国网山西省电力公司阳泉供电公司 | Transmission line induction type automatic snow-removing shockproof hammer and transmission line system |
| CN116231571B (en) * | 2023-03-27 | 2023-09-26 | 国网安徽省电力有限公司全椒县供电公司 | A power grid wiring device |
| CN116231571A (en) * | 2023-03-27 | 2023-06-06 | 国网安徽省电力有限公司全椒县供电公司 | A power grid wiring device |
| CN116632720A (en) * | 2023-07-18 | 2023-08-22 | 国网安徽省电力有限公司巢湖市供电公司 | An intelligent inspection device for high-voltage lines |
| CN116632720B (en) * | 2023-07-18 | 2023-09-15 | 国网安徽省电力有限公司巢湖市供电公司 | Intelligent inspection device for high-voltage line |
| CN116914677A (en) * | 2023-09-12 | 2023-10-20 | 长春晟德科技有限公司 | Icing cleaning device for surface of power transmission wire |
| CN116914677B (en) * | 2023-09-12 | 2023-11-17 | 长春晟德科技有限公司 | Icing cleaning device for surface of power transmission wire |
| CN118763589A (en) * | 2024-09-06 | 2024-10-11 | 国机传感科技有限公司 | Cable ice removal device |
| CN118825905A (en) * | 2024-09-20 | 2024-10-22 | 河南海平线科技有限公司 | Rail-type electric power automatic inspection robot based on ray technology and operation method |
| CN119297910A (en) * | 2024-12-13 | 2025-01-10 | 武汉雷特科技有限公司 | A wire deicing device based on thermal ice melting |
| CN120073548A (en) * | 2025-03-13 | 2025-05-30 | 南京冉小星科技有限公司 | Power network transmission line cable detection device and system thereof |
| CN120090113A (en) * | 2025-04-30 | 2025-06-03 | 国网河南省电力公司新乡供电公司 | A deicing device for a power transmission line |
| CN120527831A (en) * | 2025-07-23 | 2025-08-22 | 山西丹旭泰电力科技有限公司 | Deicing device for power line |
Also Published As
| Publication number | Publication date |
|---|---|
| KR102231749B1 (en) | 2021-03-24 |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| KR102231749B1 (en) | Robot for Removing Ice And Snow on Transmission Line | |
| US20100243633A1 (en) | Power Line De-Icing Apparatus | |
| CA2891853C (en) | Apparatus and method for ice and frost removal from power lines | |
| US6660934B1 (en) | Power line ice-shedder | |
| CA3025558C (en) | A module for deicing a cable sheath and method for using the same | |
| EP3312418B1 (en) | A method and system for performing maintenance such as de-icing of a rotor blade of a wind turbine rotor | |
| CN103117525A (en) | Efficient powered deicing device for aerial power transmission and distribution cables | |
| KR20150125182A (en) | Ice and snow removal instrument for power line | |
| KR101921873B1 (en) | Line post insulator device | |
| EP2336996B1 (en) | Contactless infrared data transmission for wind turbines | |
| CN107742870A (en) | A kind of power transmission line crusing robot deicing control system and its control method | |
| CN107732846A (en) | A kind of control system for outage pressure transmission line automatic deicer | |
| CN107834484A (en) | A kind of deicing robot control system for integrating mechanical deicing and heating power deicing | |
| WO2003105302A1 (en) | Method and apparatus for breaking ice accretions on an aerial cable | |
| CN108565553B (en) | Communication iron tower with adjustable antenna angle | |
| KR102165533B1 (en) | Unmanned robot for structural diagnosis using surface cleaning function and vibration sensor | |
| CN113725798A (en) | Cable deicing device | |
| CN111431120A (en) | Cable deicing equipment | |
| KR20170069428A (en) | Apparatus for preventing freezing | |
| CN117996665A (en) | Deicing robot for high-voltage overhead line | |
| EA201200901A1 (en) | PROTECTIVE DEVICE FOR ELECTRICAL TRANSMISSION LINES | |
| CN215870694U (en) | Portable cable defroster | |
| CN117039776A (en) | A distribution line ice removal system and its control method | |
| CN113410811A (en) | Full-automatic cable defroster | |
| CN219492484U (en) | Wind power engineering blade monitoring mechanism |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| PA0109 | Patent application |
Patent event code: PA01091R01D Comment text: Patent Application Patent event date: 20181127 |
|
| PA0201 | Request for examination | ||
| PG1501 | Laying open of application | ||
| E902 | Notification of reason for refusal | ||
| PE0902 | Notice of grounds for rejection |
Comment text: Notification of reason for refusal Patent event date: 20200618 Patent event code: PE09021S01D |
|
| E90F | Notification of reason for final refusal | ||
| PE0902 | Notice of grounds for rejection |
Comment text: Final Notice of Reason for Refusal Patent event date: 20201228 Patent event code: PE09021S02D |
|
| E701 | Decision to grant or registration of patent right | ||
| PE0701 | Decision of registration |
Patent event code: PE07011S01D Comment text: Decision to Grant Registration Patent event date: 20210315 |
|
| GRNT | Written decision to grant | ||
| PR0701 | Registration of establishment |
Comment text: Registration of Establishment Patent event date: 20210318 Patent event code: PR07011E01D |
|
| PR1002 | Payment of registration fee |
Payment date: 20210319 End annual number: 3 Start annual number: 1 |
|
| PG1601 | Publication of registration | ||
| PR1001 | Payment of annual fee |
Payment date: 20240226 Start annual number: 4 End annual number: 4 |
|
| PR1001 | Payment of annual fee |
Payment date: 20250225 Start annual number: 5 End annual number: 5 |