KR20200085016A - 차량이 이동하지 않을시의 gps위치 보정을 통한 차량 위치 측정 방법 - Google Patents
차량이 이동하지 않을시의 gps위치 보정을 통한 차량 위치 측정 방법 Download PDFInfo
- Publication number
- KR20200085016A KR20200085016A KR1020190001013A KR20190001013A KR20200085016A KR 20200085016 A KR20200085016 A KR 20200085016A KR 1020190001013 A KR1020190001013 A KR 1020190001013A KR 20190001013 A KR20190001013 A KR 20190001013A KR 20200085016 A KR20200085016 A KR 20200085016A
- Authority
- KR
- South Korea
- Prior art keywords
- vehicle
- gps
- moving
- location
- value
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Granted
Links
Images
Classifications
-
- G—PHYSICS
- G01—MEASURING; TESTING
- G01S—RADIO DIRECTION-FINDING; RADIO NAVIGATION; DETERMINING DISTANCE OR VELOCITY BY USE OF RADIO WAVES; LOCATING OR PRESENCE-DETECTING BY USE OF THE REFLECTION OR RERADIATION OF RADIO WAVES; ANALOGOUS ARRANGEMENTS USING OTHER WAVES
- G01S19/00—Satellite radio beacon positioning systems; Determining position, velocity or attitude using signals transmitted by such systems
- G01S19/38—Determining a navigation solution using signals transmitted by a satellite radio beacon positioning system
- G01S19/39—Determining a navigation solution using signals transmitted by a satellite radio beacon positioning system the satellite radio beacon positioning system transmitting time-stamped messages, e.g. GPS [Global Positioning System], GLONASS [Global Orbiting Navigation Satellite System] or GALILEO
- G01S19/40—Correcting position, velocity or attitude
-
- G—PHYSICS
- G01—MEASURING; TESTING
- G01S—RADIO DIRECTION-FINDING; RADIO NAVIGATION; DETERMINING DISTANCE OR VELOCITY BY USE OF RADIO WAVES; LOCATING OR PRESENCE-DETECTING BY USE OF THE REFLECTION OR RERADIATION OF RADIO WAVES; ANALOGOUS ARRANGEMENTS USING OTHER WAVES
- G01S5/00—Position-fixing by co-ordinating two or more direction or position line determinations; Position-fixing by co-ordinating two or more distance determinations
- G01S5/02—Position-fixing by co-ordinating two or more direction or position line determinations; Position-fixing by co-ordinating two or more distance determinations using radio waves
- G01S5/0205—Details
- G01S5/021—Calibration, monitoring or correction
Landscapes
- Engineering & Computer Science (AREA)
- Radar, Positioning & Navigation (AREA)
- Remote Sensing (AREA)
- Physics & Mathematics (AREA)
- General Physics & Mathematics (AREA)
- Computer Networks & Wireless Communication (AREA)
- Position Fixing By Use Of Radio Waves (AREA)
- Navigation (AREA)
Abstract
구체적으로는, 이러한 차량 위치 측정 방법은 GPS 위치값을 통한 차량의 위치측정시, 차량이 이동하지 않을 경우 그 상태에서 GPS 위치구간을 제한해서 그 구간 내로 GPS 위치값을 다시 조정함으로써 차량이 이동하지 않을시의 튀어버린 GPS위치가 보정되도록 하는 것을 특징으로 한다.
그래서, 이를 통해 차량의 주행 경로 안내 시 등에, 그러한 경우에서 차량이 이동하지 않을 경우의 차량위치측정시 오차범위를 줄임으로써 차량 위치를 정확히 측정한다.
Description
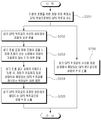
도 2는 일실시예에 따른 차량이 이동하지 않을시의 GPS위치 보정을 통한 차량 위치 측정 방법을 순서대로 도시한 플로우 차트
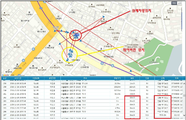
도 3은 도 2의 차량 위치 측정 방법에 적용된 일실시예에 따른 GPS위치 보정 시나리오를 설명하기 위한 도면
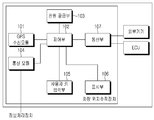
101 : GPS 수신모듈 102 : 제어부
103 : 전원 공급부 104 : 통신모듈
105 : 사용자 키 입력부 106 : 표시부
107 : 통신부
Claims (2)
- 차량운행을 위한 차량위치측정시 여러개의 움직이는 GPS위성으로부터 GPS위치값을 수신해서 운행 차량의 위치측정의 바탕정보를 얻도록 하는 제 1 단계; 및
상기 GPS위치값 수신시 GPS위치값 수신상태에서 차량의 위치를 해당되는 GPS위치값에 의해 산출해서 차량의 위치측정이 되도록 하는 제 2 단계를 포함하는 차량 위치 측정 방법에 있어서,
상기 제 1 단계 후에,
상기 GPS위치값 수신시 GPS위치값 수신상태에서 차량 진동의 유무를 판별해서 차량이 운행 중인지가 파악되도록 하는 제 1 과정;
상기 판별 결과 차량 진동이 있을시 차량진동상태에서 차량이 이동하지 않는 지의 여부를 판별하고 차량 진동이 없을 시는 판별하지 않아서 차량 진동시에 차량의 이동 여부가 파악되도록 하는 제 2 과정;
상기 판별 결과 차량이 이동하지 않을시 차량이 이동않는 상태에서 해당되는 GPS위치값을 GPS위치갱신시마다 미리 설정된 갱신위치범위의 내로 제한하여 조정해서 차량이 이동하지 않을시 튀어버린 GPS위치가 보정되도록 하는 제 3 과정; 및
상기 GPS위치값의 조정시 GPS위치값 조정상태에서 차량의 위치를 해당되는 GPS위치값에 의해 산출해서 차량이 이동하지 않을시 오차범위가 줄어들도록 차량의 위치측정이 되도록 하는 제 2' 단계를 포함하는 것을 특징으로 하는 차량이 이동하지 않을시의 GPS위치 보정을 통한 차량 위치 측정 방법. - 제 1 항에 있어서,
상기 제 3 과정의 GPS위치값의 갱신위치범위는
차량이 이동하지 않을시, 차량이 이동않는 상태에서 해당되는 최종위치부터 갱신위치까지의 거리를 기준으로 GPS위치갱신시마다 거리별로 상이하게 정해져서 갱신되는 위치별로 상기 튀어버린 GPS위치가 보정되도록 하는 것을 특징으로 하는 차량이 이동하지 않을시의 GPS위치 보정을 통한 차량 위치 측정 방법.
Priority Applications (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| KR1020190001013A KR102252394B1 (ko) | 2019-01-04 | 2019-01-04 | 차량이 이동하지 않을시의 gps위치 보정을 통한 차량 위치 측정 방법 |
Applications Claiming Priority (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| KR1020190001013A KR102252394B1 (ko) | 2019-01-04 | 2019-01-04 | 차량이 이동하지 않을시의 gps위치 보정을 통한 차량 위치 측정 방법 |
Publications (2)
| Publication Number | Publication Date |
|---|---|
| KR20200085016A true KR20200085016A (ko) | 2020-07-14 |
| KR102252394B1 KR102252394B1 (ko) | 2021-05-14 |
Family
ID=71526763
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| KR1020190001013A Active KR102252394B1 (ko) | 2019-01-04 | 2019-01-04 | 차량이 이동하지 않을시의 gps위치 보정을 통한 차량 위치 측정 방법 |
Country Status (1)
| Country | Link |
|---|---|
| KR (1) | KR102252394B1 (ko) |
Citations (3)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JPH10185600A (ja) * | 1996-12-24 | 1998-07-14 | Fujitsu Ten Ltd | 車両位置補正装置 |
| KR20010087309A (ko) * | 2000-03-03 | 2001-09-15 | 요한 요트너,헤르베르트 코네감프 | 자동차의 정지 상태를 측정하기 위한 방법 |
| JP2014142185A (ja) * | 2013-01-22 | 2014-08-07 | Panasonic Corp | 車載装置、端末装置、ナビゲーションシステム |
-
2019
- 2019-01-04 KR KR1020190001013A patent/KR102252394B1/ko active Active
Patent Citations (3)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JPH10185600A (ja) * | 1996-12-24 | 1998-07-14 | Fujitsu Ten Ltd | 車両位置補正装置 |
| KR20010087309A (ko) * | 2000-03-03 | 2001-09-15 | 요한 요트너,헤르베르트 코네감프 | 자동차의 정지 상태를 측정하기 위한 방법 |
| JP2014142185A (ja) * | 2013-01-22 | 2014-08-07 | Panasonic Corp | 車載装置、端末装置、ナビゲーションシステム |
Also Published As
| Publication number | Publication date |
|---|---|
| KR102252394B1 (ko) | 2021-05-14 |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| CN110909711B (zh) | 检测车道线位置变化的方法、装置、电子设备和存储介质 | |
| JP2024050990A (ja) | 判定装置 | |
| US9109907B2 (en) | Vehicle position recognition apparatus and method using image recognition information | |
| US11292481B2 (en) | Method and apparatus for multi vehicle sensor suite diagnosis | |
| CN108931260B (zh) | Gps欺骗时无人驾驶车辆定位安全测试系统及方法 | |
| CN103674028A (zh) | 一种室内行进轨迹的定位测试方法及装置 | |
| US9465099B2 (en) | Method for measuring position of vehicle using cloud computing | |
| CN101556160B (zh) | 可车速信号自学习的车载导航系统及方法 | |
| CN114994641B (zh) | 一种参数标定方法、装置、电子设备及存储介质 | |
| KR20150051747A (ko) | 차량의 위치 결정 방법 | |
| KR20230137439A (ko) | 군집 궤적 위치의 정확도를 평가하기 위한 컴퓨터 구현 방법 | |
| KR20190038739A (ko) | 도로 변경 지점 검출 방법 | |
| CN106371112A (zh) | 用于定位车辆的方法 | |
| KR20200083301A (ko) | 이동하는 오브젝트 센서의 정렬을 교정하기 위한 방법 | |
| CN111267912B (zh) | 基于多源信息融合的列车定位方法和系统 | |
| CN112629558B (zh) | 车辆惯导匹配矫正方法和装置、设备及存储介质 | |
| RU2667667C2 (ru) | Способ и система для настройки навигационной системы | |
| WO2018180247A1 (ja) | 出力装置、制御方法、プログラム及び記憶媒体 | |
| CN110109165B (zh) | 行驶轨迹中异常点的检测方法及装置 | |
| WO2019188886A1 (ja) | 端末装置、情報処理方法、プログラム、及び、記憶媒体 | |
| US20200363214A1 (en) | Method for using a feature-based localization map for a vehicle | |
| JP3552267B2 (ja) | 車両用位置検出装置 | |
| CN113543014A (zh) | 一种车辆卫星定位数据聚合优化系统及其方法 | |
| KR102252394B1 (ko) | 차량이 이동하지 않을시의 gps위치 보정을 통한 차량 위치 측정 방법 | |
| US11850962B2 (en) | System and a method for determining a relative pose between a primary winding structure and a secondary winding structure of a system for inductive power transfer |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| A201 | Request for examination | ||
| PA0109 | Patent application |
St.27 status event code: A-0-1-A10-A12-nap-PA0109 |
|
| PA0201 | Request for examination |
St.27 status event code: A-1-2-D10-D11-exm-PA0201 |
|
| D13-X000 | Search requested |
St.27 status event code: A-1-2-D10-D13-srh-X000 |
|
| D14-X000 | Search report completed |
St.27 status event code: A-1-2-D10-D14-srh-X000 |
|
| E902 | Notification of reason for refusal | ||
| PE0902 | Notice of grounds for rejection |
St.27 status event code: A-1-2-D10-D21-exm-PE0902 |
|
| AMND | Amendment | ||
| E13-X000 | Pre-grant limitation requested |
St.27 status event code: A-2-3-E10-E13-lim-X000 |
|
| P11-X000 | Amendment of application requested |
St.27 status event code: A-2-2-P10-P11-nap-X000 |
|
| P13-X000 | Application amended |
St.27 status event code: A-2-2-P10-P13-nap-X000 |
|
| PG1501 | Laying open of application |
St.27 status event code: A-1-1-Q10-Q12-nap-PG1501 |
|
| E90F | Notification of reason for final refusal | ||
| PE0902 | Notice of grounds for rejection |
St.27 status event code: A-1-2-D10-D21-exm-PE0902 |
|
| AMND | Amendment | ||
| P11-X000 | Amendment of application requested |
St.27 status event code: A-2-2-P10-P11-nap-X000 |
|
| P13-X000 | Application amended |
St.27 status event code: A-2-2-P10-P13-nap-X000 |
|
| E601 | Decision to refuse application | ||
| PE0601 | Decision on rejection of patent |
St.27 status event code: N-2-6-B10-B15-exm-PE0601 |
|
| X091 | Application refused [patent] | ||
| AMND | Amendment | ||
| P11-X000 | Amendment of application requested |
St.27 status event code: A-2-2-P10-P11-nap-X000 |
|
| P13-X000 | Application amended |
St.27 status event code: A-2-2-P10-P13-nap-X000 |
|
| PX0901 | Re-examination |
St.27 status event code: A-2-3-E10-E12-rex-PX0901 |
|
| PX0701 | Decision of registration after re-examination |
St.27 status event code: A-3-4-F10-F13-rex-PX0701 |
|
| X701 | Decision to grant (after re-examination) | ||
| GRNT | Written decision to grant | ||
| PR0701 | Registration of establishment |
St.27 status event code: A-2-4-F10-F11-exm-PR0701 |
|
| PR1002 | Payment of registration fee |
St.27 status event code: A-2-2-U10-U11-oth-PR1002 Fee payment year number: 1 |
|
| PG1601 | Publication of registration |
St.27 status event code: A-4-4-Q10-Q13-nap-PG1601 |
|
| PR1001 | Payment of annual fee |
St.27 status event code: A-4-4-U10-U11-oth-PR1001 Fee payment year number: 4 |
|
| R18-X000 | Changes to party contact information recorded |
St.27 status event code: A-5-5-R10-R18-oth-X000 |
|
| PR1001 | Payment of annual fee |
St.27 status event code: A-4-4-U10-U11-oth-PR1001 Fee payment year number: 5 |
|
| PR1001 | Payment of annual fee |
St.27 status event code: A-4-4-U10-U11-oth-PR1001 Fee payment year number: 6 |