KR20200094678A - 웨어러블 보행 보조 로봇 제어 장치 및 방법 - Google Patents
웨어러블 보행 보조 로봇 제어 장치 및 방법 Download PDFInfo
- Publication number
- KR20200094678A KR20200094678A KR1020200009749A KR20200009749A KR20200094678A KR 20200094678 A KR20200094678 A KR 20200094678A KR 1020200009749 A KR1020200009749 A KR 1020200009749A KR 20200009749 A KR20200009749 A KR 20200009749A KR 20200094678 A KR20200094678 A KR 20200094678A
- Authority
- KR
- South Korea
- Prior art keywords
- robot
- user
- muscle
- wearable walking
- driving power
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Granted
Links
Images


Classifications
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B25—HAND TOOLS; PORTABLE POWER-DRIVEN TOOLS; MANIPULATORS
- B25J—MANIPULATORS; CHAMBERS PROVIDED WITH MANIPULATION DEVICES
- B25J9/00—Program-controlled manipulators
- B25J9/16—Program controls
- B25J9/1602—Program controls characterised by the control system, structure, architecture
-
- A61B5/0488—
-
- A—HUMAN NECESSITIES
- A61—MEDICAL OR VETERINARY SCIENCE; HYGIENE
- A61B—DIAGNOSIS; SURGERY; IDENTIFICATION
- A61B5/00—Measuring for diagnostic purposes; Identification of persons
- A61B5/103—Measuring devices for testing the shape, pattern, colour, size or movement of the body or parts thereof, for diagnostic purposes
- A61B5/11—Measuring movement of the entire body or parts thereof, e.g. head or hand tremor or mobility of a limb
-
- A—HUMAN NECESSITIES
- A61—MEDICAL OR VETERINARY SCIENCE; HYGIENE
- A61B—DIAGNOSIS; SURGERY; IDENTIFICATION
- A61B5/00—Measuring for diagnostic purposes; Identification of persons
- A61B5/24—Detecting, measuring or recording bioelectric or biomagnetic signals of the body or parts thereof
- A61B5/316—Modalities, i.e. specific diagnostic methods
- A61B5/389—Electromyography [EMG]
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B25—HAND TOOLS; PORTABLE POWER-DRIVEN TOOLS; MANIPULATORS
- B25J—MANIPULATORS; CHAMBERS PROVIDED WITH MANIPULATION DEVICES
- B25J13/00—Controls for manipulators
- B25J13/08—Controls for manipulators by means of sensing devices, e.g. viewing or touching devices
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B25—HAND TOOLS; PORTABLE POWER-DRIVEN TOOLS; MANIPULATORS
- B25J—MANIPULATORS; CHAMBERS PROVIDED WITH MANIPULATION DEVICES
- B25J9/00—Program-controlled manipulators
- B25J9/0006—Exoskeletons, i.e. resembling a human figure
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B25—HAND TOOLS; PORTABLE POWER-DRIVEN TOOLS; MANIPULATORS
- B25J—MANIPULATORS; CHAMBERS PROVIDED WITH MANIPULATION DEVICES
- B25J9/00—Program-controlled manipulators
- B25J9/16—Program controls
- B25J9/1628—Program controls characterised by the control loop
- B25J9/1633—Program controls characterised by the control loop compliant, force, torque control, e.g. combined with position control
Landscapes
- Engineering & Computer Science (AREA)
- Health & Medical Sciences (AREA)
- Life Sciences & Earth Sciences (AREA)
- Robotics (AREA)
- Mechanical Engineering (AREA)
- Molecular Biology (AREA)
- Medical Informatics (AREA)
- Veterinary Medicine (AREA)
- Physics & Mathematics (AREA)
- Public Health (AREA)
- Biophysics (AREA)
- Pathology (AREA)
- Biomedical Technology (AREA)
- Heart & Thoracic Surgery (AREA)
- General Health & Medical Sciences (AREA)
- Animal Behavior & Ethology (AREA)
- Surgery (AREA)
- Human Computer Interaction (AREA)
- Dentistry (AREA)
- Physiology (AREA)
- Oral & Maxillofacial Surgery (AREA)
- Automation & Control Theory (AREA)
- Rehabilitation Tools (AREA)
Abstract
Description
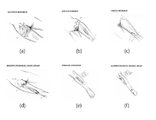
도 2는 본 발명의 일 실시예에 따라 근력을 측정하는 근육 및 전극 부착 지점을 설명하기 위한 도면이다.
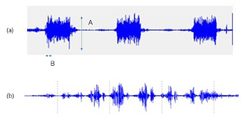
도 3은 정상인과 환자의 근전도 신호를 측정한 예를 비교하여 도시하는 도면이다.
도 4는 본 발명의 다른 실시예에 따른 웨어러블 보행 보조 로봇 제어 방법의 흐름도이다.
110: 생체신호 감지부
120: 신호 분석부
130: 로봇 구동 제어부
140: 데이터 입력부
Claims (8)
- 웨어러블 보행 보조 로봇을 착용한 사용자의 생체신호를 감지하는 생체신호 감지부;
상기 생체신호 감지부에 의해 감지한 생체신호를 기초로 사용자의 근력을 분석하는 신호 분석부; 및
상기 신호 분석부에 의해 분석된 사용자의 근력에 따라 상기 웨어러블 보행 보조 로봇의 구동 파워를 제어하는 로봇 구동 제어부를 포함하는 웨어러블 보행 보조 로봇 제어 장치.
- 제 1 항에 있어서,
상기 생체신호 감지부는 복수의 표면 근전도 센서를 포함하며,
상기 복수의 표면 근전도 센서 각각의 전극은 큰볼기근(Gluteus maximus), 넙다리곧은근(Rectus femoris), 안쪽넓은근(Vastus medialis), 넙다리두갈래근(Biceps femoris), 앞정강근(Tibialis anterior) 및 장딴지근(Gastrocnemius)의 근력을 측정하기 위해 부착되는 것을 특징으로 하는 웨어러블 보행 보조 로봇 제어 장치.
- 제 2 항에 있어서,
상기 신호 분석부는 상기 생체신호 감지부에 의해 감지된 근전도 신호의 진폭(amplitude), 지속기간(duration), 간섭양상(interference pattern) 및 위상(phase)을 기 설정된 정상 범위값과 비교하여 상기 대상 근육의 기능을 정량화하는 것을 특징으로 하는 웨어러블 보행 보조 로봇 제어 장치.
- 제 3 항에 있어서,
상기 웨어러블 보행 보조 로봇의 제어를 위해 필요한 데이터를 입력 받기 위한 데이터 입력부를 더 포함하며,
상기 신호 분석부는 정량화된 사용자의 근력과 상기 데이터 입력부를 통해 입력된 근력평가척도(medical research council score)를 기초로 사용자의 각 대상 근육별 근력이 기 설정된 복수의 단계 중 어느 단계에 속하는지 판단하는 것을 특징으로 하는 웨어러블 보행 보조 로봇 제어 장치.
- 제 4 항에 있어서,
상기 로봇 구동 제어부는 상기 신호 분석부에 의해 판단된 각 대상 근육별 근력이 속하는 단계에 따라서 상기 웨어러블 보행 보조 로봇의 제어 모드를 기 설정된 복수의 제어 모드 중 어느 하나로 설정한 후, 설정된 제어 모드에 따라서 웨어러블 보행 보조 로봇의 구동 파워를 제어하는 것을 특징으로 하는 웨어러블 보행 보조 로봇 제어 장치.
- 제 1 항에 있어서,
상기 로봇 구동 제어부는 웨어러블 보행 보조 로봇에 의해 의도한 동작을 수행하기 위해 필요한 구동 파워에서 상기 사용자의 근력을 제한 구동 파워보다 기 설정된 정도 낮도록 상기 구동 파워를 결정하는 것을 특징으로 하는 웨어러블 보행 보조 로봇 제어 장치.
- 기 설정된 구동 파워로 사용자에 의해 착용된 웨어러블 보행 보조 로봇을 구동시키는 단계;
상기 사용자의 움직임에 따른 생체신호를 획득하는 단계;
상기 생체신호를 기초로 사용자의 근력을 분석하는 단계; 및
상기 사용자의 근력에 따라 상기 웨어러블 보행 보조 로봇의 구동 파워를 제어하는 단계를 포함하는 웨어러블 보행 보조 로봇 제어 방법.
- 제 7 항에 있어서, 상기 구동 파워를 제어하는 단계는,
상기 웨어러블 보행 보조 로봇에 의해 의도한 동작을 수행하기 위해 필요한 구동 파워에서 상기 사용자의 근력을 제한 구동 파워보다 기 설정된 정도 낮도록 상기 구동 파워를 결정하는 것을 특징으로 하는 웨어러블 보행 보조 로봇 제어 방법.
Applications Claiming Priority (2)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| KR1020190011081 | 2019-01-29 | ||
| KR20190011081 | 2019-01-29 |
Publications (2)
| Publication Number | Publication Date |
|---|---|
| KR20200094678A true KR20200094678A (ko) | 2020-08-07 |
| KR102261608B1 KR102261608B1 (ko) | 2021-06-08 |
Family
ID=72050129
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| KR1020200009749A Active KR102261608B1 (ko) | 2019-01-29 | 2020-01-28 | 웨어러블 보행 보조 로봇 제어 장치 및 방법 |
Country Status (1)
| Country | Link |
|---|---|
| KR (1) | KR102261608B1 (ko) |
Cited By (3)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| KR20220073925A (ko) * | 2020-11-27 | 2022-06-03 | (주) 로임시스템 | 생체신호 이원화 처리 장치 |
| CN114732679A (zh) * | 2021-01-07 | 2022-07-12 | 丰田自动车株式会社 | 电动辅助装置以及控制装置 |
| CN116372928A (zh) * | 2023-04-17 | 2023-07-04 | 浙江科技学院 | 基于表面微小电信号的多自由度控制系统 |
Citations (1)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| KR20160068795A (ko) * | 2013-10-09 | 2016-06-15 | 엠씨10, 인크 | 곡면부착형 센서를 포함하는 다기능 장비 |
-
2020
- 2020-01-28 KR KR1020200009749A patent/KR102261608B1/ko active Active
Patent Citations (1)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| KR20160068795A (ko) * | 2013-10-09 | 2016-06-15 | 엠씨10, 인크 | 곡면부착형 센서를 포함하는 다기능 장비 |
Cited By (4)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| KR20220073925A (ko) * | 2020-11-27 | 2022-06-03 | (주) 로임시스템 | 생체신호 이원화 처리 장치 |
| CN114732679A (zh) * | 2021-01-07 | 2022-07-12 | 丰田自动车株式会社 | 电动辅助装置以及控制装置 |
| CN114732679B (zh) * | 2021-01-07 | 2024-04-26 | 丰田自动车株式会社 | 电动辅助装置以及控制装置 |
| CN116372928A (zh) * | 2023-04-17 | 2023-07-04 | 浙江科技学院 | 基于表面微小电信号的多自由度控制系统 |
Also Published As
| Publication number | Publication date |
|---|---|
| KR102261608B1 (ko) | 2021-06-08 |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| US11622905B2 (en) | Proportional joint-moment control for powered exoskeletons and prostheses | |
| Strazza et al. | Surface-EMG analysis for the quantification of thigh muscle dynamic co-contractions during normal gait | |
| US10434027B2 (en) | Recognition method of human walking speed intention from surface electromyogram signals of plantar flexor and walking speed control method of a lower-limb exoskeleton robot | |
| Davis | Reflections on clinical gait analysis | |
| Kwon et al. | Comparison of muscle activity during walking in subjects with and without diabetic neuropathy | |
| Kao et al. | Motor adaptation during dorsiflexion-assisted walking with a powered orthosis | |
| Godiyal et al. | Force myography based novel strategy for locomotion classification | |
| CN110522457B (zh) | 一种基于电机电流、传感器反馈的实时步态分析方法 | |
| Krishnan et al. | A pilot study on the feasibility of robot-aided leg motor training to facilitate active participation | |
| Grazi et al. | Gastrocnemius myoelectric control of a robotic hip exoskeleton can reduce the user's lower-limb muscle activities at push off | |
| KR101841011B1 (ko) | 하지 보조로봇의 제어방법 | |
| KR102261608B1 (ko) | 웨어러블 보행 보조 로봇 제어 장치 및 방법 | |
| Jahanandish et al. | Ultrasound features of skeletal muscle can predict kinematics of upcoming lower-limb motion | |
| Godiyal et al. | Analysis of force myography based locomotion patterns | |
| Di Tommaso et al. | Biomechanics of exoskeleton-assisted treadmill walking | |
| Di Nardo et al. | Surface EMG patterns for quantification of thigh muscle co-contraction in school-age children: Normative data during walking | |
| KR102467246B1 (ko) | 근육 제어 장치 및 그것의 동작 방법 | |
| KR20170098058A (ko) | 생체인식기반 맞춤형 재활 시스템 | |
| Mazumder et al. | Multi-channel fusion based adaptive gait trajectory generation using wearable sensors | |
| CN120267277B (zh) | 行走器的助力调控方法、系统及存储介质 | |
| Yu et al. | Analysis of muscle activity during gait cycle using fuzzy rule-based reasoning | |
| Chaparro-Cárdenas et al. | Characterization of muscle fatigue in the lower limb by sEMG and angular position using the WFD protocol | |
| Wang et al. | Qualitative evaluations of gait rehabilitation via EMG muscle activation pattern: Repetition, symmetry, and smoothness | |
| Li et al. | Gait and sEMG characteristics of lower limbs in children with unilateral spastic cerebral palsy during walking | |
| Tong et al. | BP-AR-based human joint angle estimation using multi-channel sEMG |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| A201 | Request for examination | ||
| PA0109 | Patent application |
St.27 status event code: A-0-1-A10-A12-nap-PA0109 |
|
| PA0201 | Request for examination |
St.27 status event code: A-1-2-D10-D11-exm-PA0201 |
|
| PG1501 | Laying open of application |
St.27 status event code: A-1-1-Q10-Q12-nap-PG1501 |
|
| D13-X000 | Search requested |
St.27 status event code: A-1-2-D10-D13-srh-X000 |
|
| P22-X000 | Classification modified |
St.27 status event code: A-2-2-P10-P22-nap-X000 |
|
| P22-X000 | Classification modified |
St.27 status event code: A-2-2-P10-P22-nap-X000 |
|
| D14-X000 | Search report completed |
St.27 status event code: A-1-2-D10-D14-srh-X000 |
|
| E902 | Notification of reason for refusal | ||
| PE0902 | Notice of grounds for rejection |
St.27 status event code: A-1-2-D10-D21-exm-PE0902 |
|
| AMND | Amendment | ||
| E13-X000 | Pre-grant limitation requested |
St.27 status event code: A-2-3-E10-E13-lim-X000 |
|
| P11-X000 | Amendment of application requested |
St.27 status event code: A-2-2-P10-P11-nap-X000 |
|
| P13-X000 | Application amended |
St.27 status event code: A-2-2-P10-P13-nap-X000 |
|
| E601 | Decision to refuse application | ||
| PE0601 | Decision on rejection of patent |
St.27 status event code: N-2-6-B10-B15-exm-PE0601 |
|
| X091 | Application refused [patent] | ||
| AMND | Amendment | ||
| P11-X000 | Amendment of application requested |
St.27 status event code: A-2-2-P10-P11-nap-X000 |
|
| P13-X000 | Application amended |
St.27 status event code: A-2-2-P10-P13-nap-X000 |
|
| PX0901 | Re-examination |
St.27 status event code: A-2-3-E10-E12-rex-PX0901 |
|
| PX0701 | Decision of registration after re-examination |
St.27 status event code: A-3-4-F10-F13-rex-PX0701 |
|
| X701 | Decision to grant (after re-examination) | ||
| GRNT | Written decision to grant | ||
| PR0701 | Registration of establishment |
St.27 status event code: A-2-4-F10-F11-exm-PR0701 |
|
| PR1002 | Payment of registration fee |
St.27 status event code: A-2-2-U10-U11-oth-PR1002 Fee payment year number: 1 |
|
| PG1601 | Publication of registration |
St.27 status event code: A-4-4-Q10-Q13-nap-PG1601 |
|
| R17-X000 | Change to representative recorded |
St.27 status event code: A-5-5-R10-R17-oth-X000 |
|
| P22-X000 | Classification modified |
St.27 status event code: A-4-4-P10-P22-nap-X000 |
|
| PR1001 | Payment of annual fee |
St.27 status event code: A-4-4-U10-U11-oth-PR1001 Fee payment year number: 4 |
|
| PR1001 | Payment of annual fee |
St.27 status event code: A-4-4-U10-U11-oth-PR1001 Fee payment year number: 5 |
|
| U11 | Full renewal or maintenance fee paid |
Free format text: ST27 STATUS EVENT CODE: A-4-4-U10-U11-OTH-PR1001 (AS PROVIDED BY THE NATIONAL OFFICE) Year of fee payment: 5 |