KR20200099611A - 로봇 자율 모션 계획 및 내비게이션을 위한 시스템 및 방법들 - Google Patents
로봇 자율 모션 계획 및 내비게이션을 위한 시스템 및 방법들 Download PDFInfo
- Publication number
- KR20200099611A KR20200099611A KR1020207022386A KR20207022386A KR20200099611A KR 20200099611 A KR20200099611 A KR 20200099611A KR 1020207022386 A KR1020207022386 A KR 1020207022386A KR 20207022386 A KR20207022386 A KR 20207022386A KR 20200099611 A KR20200099611 A KR 20200099611A
- Authority
- KR
- South Korea
- Prior art keywords
- robot
- human activity
- data
- environment
- locations
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Granted
Links
Images


Classifications
-
- G—PHYSICS
- G01—MEASURING; TESTING
- G01C—MEASURING DISTANCES, LEVELS OR BEARINGS; SURVEYING; NAVIGATION; GYROSCOPIC INSTRUMENTS; PHOTOGRAMMETRY OR VIDEOGRAMMETRY
- G01C21/00—Navigation; Navigational instruments not provided for in groups G01C1/00 - G01C19/00
- G01C21/26—Navigation; Navigational instruments not provided for in groups G01C1/00 - G01C19/00 specially adapted for navigation in a road network
- G01C21/34—Route searching; Route guidance
- G01C21/3453—Special cost functions, i.e. other than distance or default speed limit of road segments
-
- G—PHYSICS
- G01—MEASURING; TESTING
- G01C—MEASURING DISTANCES, LEVELS OR BEARINGS; SURVEYING; NAVIGATION; GYROSCOPIC INSTRUMENTS; PHOTOGRAMMETRY OR VIDEOGRAMMETRY
- G01C21/00—Navigation; Navigational instruments not provided for in groups G01C1/00 - G01C19/00
- G01C21/26—Navigation; Navigational instruments not provided for in groups G01C1/00 - G01C19/00 specially adapted for navigation in a road network
- G01C21/34—Route searching; Route guidance
- G01C21/3453—Special cost functions, i.e. other than distance or default speed limit of road segments
- G01C21/3461—Preferred or disfavoured areas, e.g. dangerous zones, toll or emission zones, intersections, manoeuvre types or segments such as motorways, toll roads or ferries
-
- G—PHYSICS
- G05—CONTROLLING; REGULATING
- G05D—SYSTEMS FOR CONTROLLING OR REGULATING NON-ELECTRIC VARIABLES
- G05D1/00—Control of position, course, altitude or attitude of land, water, air or space vehicles, e.g. using automatic pilots
- G05D1/60—Intended control result
- G05D1/644—Optimisation of travel parameters, e.g. of energy consumption, journey time or distance
-
- G—PHYSICS
- G05—CONTROLLING; REGULATING
- G05D—SYSTEMS FOR CONTROLLING OR REGULATING NON-ELECTRIC VARIABLES
- G05D1/00—Control of position, course, altitude or attitude of land, water, air or space vehicles, e.g. using automatic pilots
- G05D1/02—Control of position or course in two dimensions
- G05D1/021—Control of position or course in two dimensions specially adapted to land vehicles
- G05D1/0212—Control of position or course in two dimensions specially adapted to land vehicles with means for defining a desired trajectory
-
- G—PHYSICS
- G01—MEASURING; TESTING
- G01C—MEASURING DISTANCES, LEVELS OR BEARINGS; SURVEYING; NAVIGATION; GYROSCOPIC INSTRUMENTS; PHOTOGRAMMETRY OR VIDEOGRAMMETRY
- G01C21/00—Navigation; Navigational instruments not provided for in groups G01C1/00 - G01C19/00
- G01C21/26—Navigation; Navigational instruments not provided for in groups G01C1/00 - G01C19/00 specially adapted for navigation in a road network
- G01C21/34—Route searching; Route guidance
- G01C21/3453—Special cost functions, i.e. other than distance or default speed limit of road segments
- G01C21/3492—Special cost functions, i.e. other than distance or default speed limit of road segments employing speed data or traffic data, e.g. real-time or historical
-
- G—PHYSICS
- G05—CONTROLLING; REGULATING
- G05B—CONTROL OR REGULATING SYSTEMS IN GENERAL; FUNCTIONAL ELEMENTS OF SUCH SYSTEMS; MONITORING OR TESTING ARRANGEMENTS FOR SUCH SYSTEMS OR ELEMENTS
- G05B19/00—Program-control systems
- G05B19/02—Program-control systems electric
- G05B19/04—Program control other than numerical control, i.e. in sequence controllers or logic controllers
- G05B19/048—Monitoring; Safety
-
- G—PHYSICS
- G05—CONTROLLING; REGULATING
- G05D—SYSTEMS FOR CONTROLLING OR REGULATING NON-ELECTRIC VARIABLES
- G05D1/00—Control of position, course, altitude or attitude of land, water, air or space vehicles, e.g. using automatic pilots
- G05D1/0055—Control of position, course, altitude or attitude of land, water, air or space vehicles, e.g. using automatic pilots with safety arrangements
- G05D1/0061—Control of position, course, altitude or attitude of land, water, air or space vehicles, e.g. using automatic pilots with safety arrangements for transition from automatic pilot to manual pilot and vice versa
-
- G—PHYSICS
- G05—CONTROLLING; REGULATING
- G05D—SYSTEMS FOR CONTROLLING OR REGULATING NON-ELECTRIC VARIABLES
- G05D1/00—Control of position, course, altitude or attitude of land, water, air or space vehicles, e.g. using automatic pilots
- G05D1/02—Control of position or course in two dimensions
- G05D1/021—Control of position or course in two dimensions specially adapted to land vehicles
- G05D1/0212—Control of position or course in two dimensions specially adapted to land vehicles with means for defining a desired trajectory
- G05D1/0217—Control of position or course in two dimensions specially adapted to land vehicles with means for defining a desired trajectory in accordance with energy consumption, time reduction or distance reduction criteria
-
- G—PHYSICS
- G05—CONTROLLING; REGULATING
- G05D—SYSTEMS FOR CONTROLLING OR REGULATING NON-ELECTRIC VARIABLES
- G05D1/00—Control of position, course, altitude or attitude of land, water, air or space vehicles, e.g. using automatic pilots
- G05D1/02—Control of position or course in two dimensions
- G05D1/021—Control of position or course in two dimensions specially adapted to land vehicles
- G05D1/0212—Control of position or course in two dimensions specially adapted to land vehicles with means for defining a desired trajectory
- G05D1/0221—Control of position or course in two dimensions specially adapted to land vehicles with means for defining a desired trajectory involving a learning process
-
- G—PHYSICS
- G05—CONTROLLING; REGULATING
- G05D—SYSTEMS FOR CONTROLLING OR REGULATING NON-ELECTRIC VARIABLES
- G05D1/00—Control of position, course, altitude or attitude of land, water, air or space vehicles, e.g. using automatic pilots
- G05D1/02—Control of position or course in two dimensions
- G05D1/021—Control of position or course in two dimensions specially adapted to land vehicles
- G05D1/0231—Control of position or course in two dimensions specially adapted to land vehicles using optical position detecting means
- G05D1/0246—Control of position or course in two dimensions specially adapted to land vehicles using optical position detecting means using a video camera in combination with image processing means
-
- G—PHYSICS
- G05—CONTROLLING; REGULATING
- G05D—SYSTEMS FOR CONTROLLING OR REGULATING NON-ELECTRIC VARIABLES
- G05D1/00—Control of position, course, altitude or attitude of land, water, air or space vehicles, e.g. using automatic pilots
- G05D1/02—Control of position or course in two dimensions
- G05D1/021—Control of position or course in two dimensions specially adapted to land vehicles
- G05D1/0276—Control of position or course in two dimensions specially adapted to land vehicles using signals provided by a source external to the vehicle
- G05D1/028—Control of position or course in two dimensions specially adapted to land vehicles using signals provided by a source external to the vehicle using a RF signal
- G05D1/0282—Control of position or course in two dimensions specially adapted to land vehicles using signals provided by a source external to the vehicle using a RF signal generated in a local control room
-
- G—PHYSICS
- G05—CONTROLLING; REGULATING
- G05D—SYSTEMS FOR CONTROLLING OR REGULATING NON-ELECTRIC VARIABLES
- G05D1/00—Control of position, course, altitude or attitude of land, water, air or space vehicles, e.g. using automatic pilots
- G05D1/20—Control system inputs
- G05D1/22—Command input arrangements
- G05D1/229—Command input data, e.g. waypoints
-
- G—PHYSICS
- G05—CONTROLLING; REGULATING
- G05D—SYSTEMS FOR CONTROLLING OR REGULATING NON-ELECTRIC VARIABLES
- G05D1/00—Control of position, course, altitude or attitude of land, water, air or space vehicles, e.g. using automatic pilots
- G05D1/20—Control system inputs
- G05D1/24—Arrangements for determining position or orientation
- G05D1/243—Means capturing signals occurring naturally from the environment, e.g. ambient optical, acoustic, gravitational or magnetic signals
-
- G—PHYSICS
- G05—CONTROLLING; REGULATING
- G05D—SYSTEMS FOR CONTROLLING OR REGULATING NON-ELECTRIC VARIABLES
- G05D1/00—Control of position, course, altitude or attitude of land, water, air or space vehicles, e.g. using automatic pilots
- G05D1/60—Intended control result
- G05D1/617—Safety or protection, e.g. defining protection zones around obstacles or avoiding hazards
-
- G—PHYSICS
- G05—CONTROLLING; REGULATING
- G05D—SYSTEMS FOR CONTROLLING OR REGULATING NON-ELECTRIC VARIABLES
- G05D1/00—Control of position, course, altitude or attitude of land, water, air or space vehicles, e.g. using automatic pilots
- G05D1/60—Intended control result
- G05D1/69—Coordinated control of the position or course of two or more vehicles
- G05D1/698—Control allocation
- G05D1/6987—Control allocation by centralised control off-board any of the vehicles
-
- G—PHYSICS
- G05—CONTROLLING; REGULATING
- G05D—SYSTEMS FOR CONTROLLING OR REGULATING NON-ELECTRIC VARIABLES
- G05D1/00—Control of position, course, altitude or attitude of land, water, air or space vehicles, e.g. using automatic pilots
- G05D1/80—Arrangements for reacting to or preventing system or operator failure
- G05D1/81—Handing over between on-board automatic and on-board manual control
-
- G—PHYSICS
- G06—COMPUTING OR CALCULATING; COUNTING
- G06Q—INFORMATION AND COMMUNICATION TECHNOLOGY [ICT] SPECIALLY ADAPTED FOR ADMINISTRATIVE, COMMERCIAL, FINANCIAL, MANAGERIAL OR SUPERVISORY PURPOSES; SYSTEMS OR METHODS SPECIALLY ADAPTED FOR ADMINISTRATIVE, COMMERCIAL, FINANCIAL, MANAGERIAL OR SUPERVISORY PURPOSES, NOT OTHERWISE PROVIDED FOR
- G06Q10/00—Administration; Management
- G06Q10/06—Resources, workflows, human or project management; Enterprise or organisation planning; Enterprise or organisation modelling
-
- G—PHYSICS
- G06—COMPUTING OR CALCULATING; COUNTING
- G06Q—INFORMATION AND COMMUNICATION TECHNOLOGY [ICT] SPECIALLY ADAPTED FOR ADMINISTRATIVE, COMMERCIAL, FINANCIAL, MANAGERIAL OR SUPERVISORY PURPOSES; SYSTEMS OR METHODS SPECIALLY ADAPTED FOR ADMINISTRATIVE, COMMERCIAL, FINANCIAL, MANAGERIAL OR SUPERVISORY PURPOSES, NOT OTHERWISE PROVIDED FOR
- G06Q10/00—Administration; Management
- G06Q10/06—Resources, workflows, human or project management; Enterprise or organisation planning; Enterprise or organisation modelling
- G06Q10/063—Operations research, analysis or management
- G06Q10/0631—Resource planning, allocation, distributing or scheduling for enterprises or organisations
-
- G—PHYSICS
- G05—CONTROLLING; REGULATING
- G05B—CONTROL OR REGULATING SYSTEMS IN GENERAL; FUNCTIONAL ELEMENTS OF SUCH SYSTEMS; MONITORING OR TESTING ARRANGEMENTS FOR SUCH SYSTEMS OR ELEMENTS
- G05B2219/00—Program-control systems
- G05B2219/30—Nc systems
- G05B2219/40—Robotics, robotics mapping to robotics vision
- G05B2219/40523—Path motion planning, path in space followed by tip of robot
-
- Y—GENERAL TAGGING OF NEW TECHNOLOGICAL DEVELOPMENTS; GENERAL TAGGING OF CROSS-SECTIONAL TECHNOLOGIES SPANNING OVER SEVERAL SECTIONS OF THE IPC; TECHNICAL SUBJECTS COVERED BY FORMER USPC CROSS-REFERENCE ART COLLECTIONS [XRACs] AND DIGESTS
- Y10—TECHNICAL SUBJECTS COVERED BY FORMER USPC
- Y10S—TECHNICAL SUBJECTS COVERED BY FORMER USPC CROSS-REFERENCE ART COLLECTIONS [XRACs] AND DIGESTS
- Y10S901/00—Robots
- Y10S901/01—Mobile robot
-
- Y—GENERAL TAGGING OF NEW TECHNOLOGICAL DEVELOPMENTS; GENERAL TAGGING OF CROSS-SECTIONAL TECHNOLOGIES SPANNING OVER SEVERAL SECTIONS OF THE IPC; TECHNICAL SUBJECTS COVERED BY FORMER USPC CROSS-REFERENCE ART COLLECTIONS [XRACs] AND DIGESTS
- Y10—TECHNICAL SUBJECTS COVERED BY FORMER USPC
- Y10S—TECHNICAL SUBJECTS COVERED BY FORMER USPC CROSS-REFERENCE ART COLLECTIONS [XRACs] AND DIGESTS
- Y10S901/00—Robots
- Y10S901/46—Sensing device
- Y10S901/47—Optical
Landscapes
- Engineering & Computer Science (AREA)
- Remote Sensing (AREA)
- Radar, Positioning & Navigation (AREA)
- Physics & Mathematics (AREA)
- General Physics & Mathematics (AREA)
- Automation & Control Theory (AREA)
- Business, Economics & Management (AREA)
- Aviation & Aerospace Engineering (AREA)
- Human Resources & Organizations (AREA)
- Economics (AREA)
- Entrepreneurship & Innovation (AREA)
- Strategic Management (AREA)
- Development Economics (AREA)
- Operations Research (AREA)
- Quality & Reliability (AREA)
- Tourism & Hospitality (AREA)
- General Business, Economics & Management (AREA)
- Theoretical Computer Science (AREA)
- Marketing (AREA)
- Game Theory and Decision Science (AREA)
- Educational Administration (AREA)
- Computer Vision & Pattern Recognition (AREA)
- Multimedia (AREA)
- Electromagnetism (AREA)
- Control Of Position, Course, Altitude, Or Attitude Of Moving Bodies (AREA)
Abstract
Description
도 1은 본 개시물의 양태들에 따른 로봇 및 네트워크된(networked) 환경의 개략도.
도 2는 본 개시물의 양태들에 따른 도 1의 내비게이션 시스템과 작업 계획(task planning)으로 사용하기에 적합한 프로세서 기반의 시스템의 블록도.
도 3은 본 개시물의 양태들에 따른 사람 활동을 묘사하는 히트 맵(heat map)들의 예들을 도시하는 도면.
도 4는 본 개시물의 양태들에 따른, 사람 활동을 묘사하는 은닉 마르코프 모델(Hidden Markov Model)의 일 예를 도시하는 도면.
도 5는 본 개시물의 양태들에 따른 사람 활동 맵의 일 예를 도시하는 도면.
도 6은 본 개시물의 양태들에 따른 비용 맵(cost map)의 일 예를 도시하는 도면.
도 7은 본 개시물의 양태들에 따른 공유된 환경에서의 로봇의 내비게이션을 행할 때의 단계들의 프로세스 흐름(process flow)을 도시하는 도면.

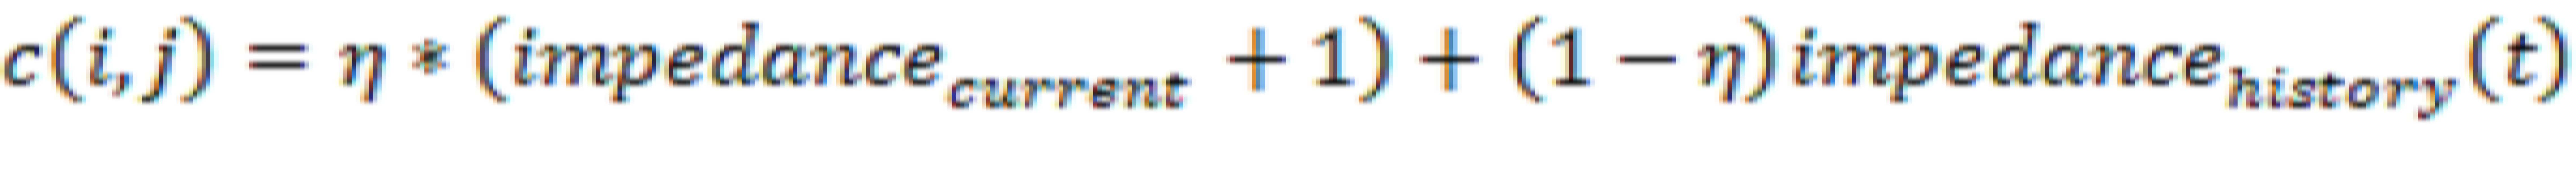

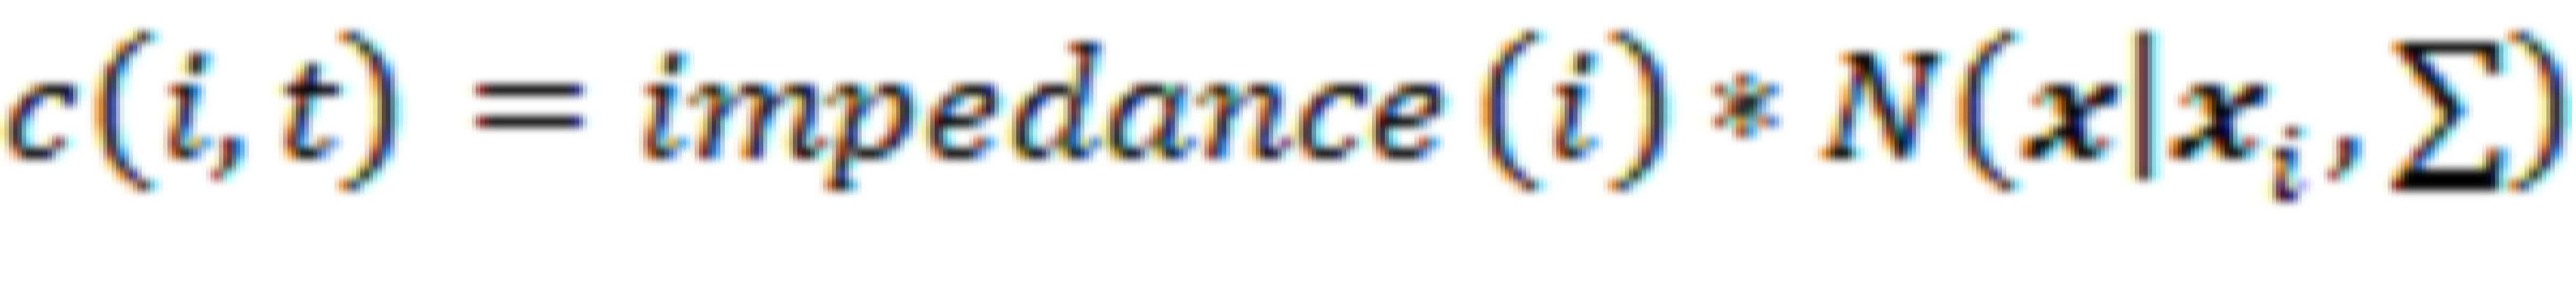
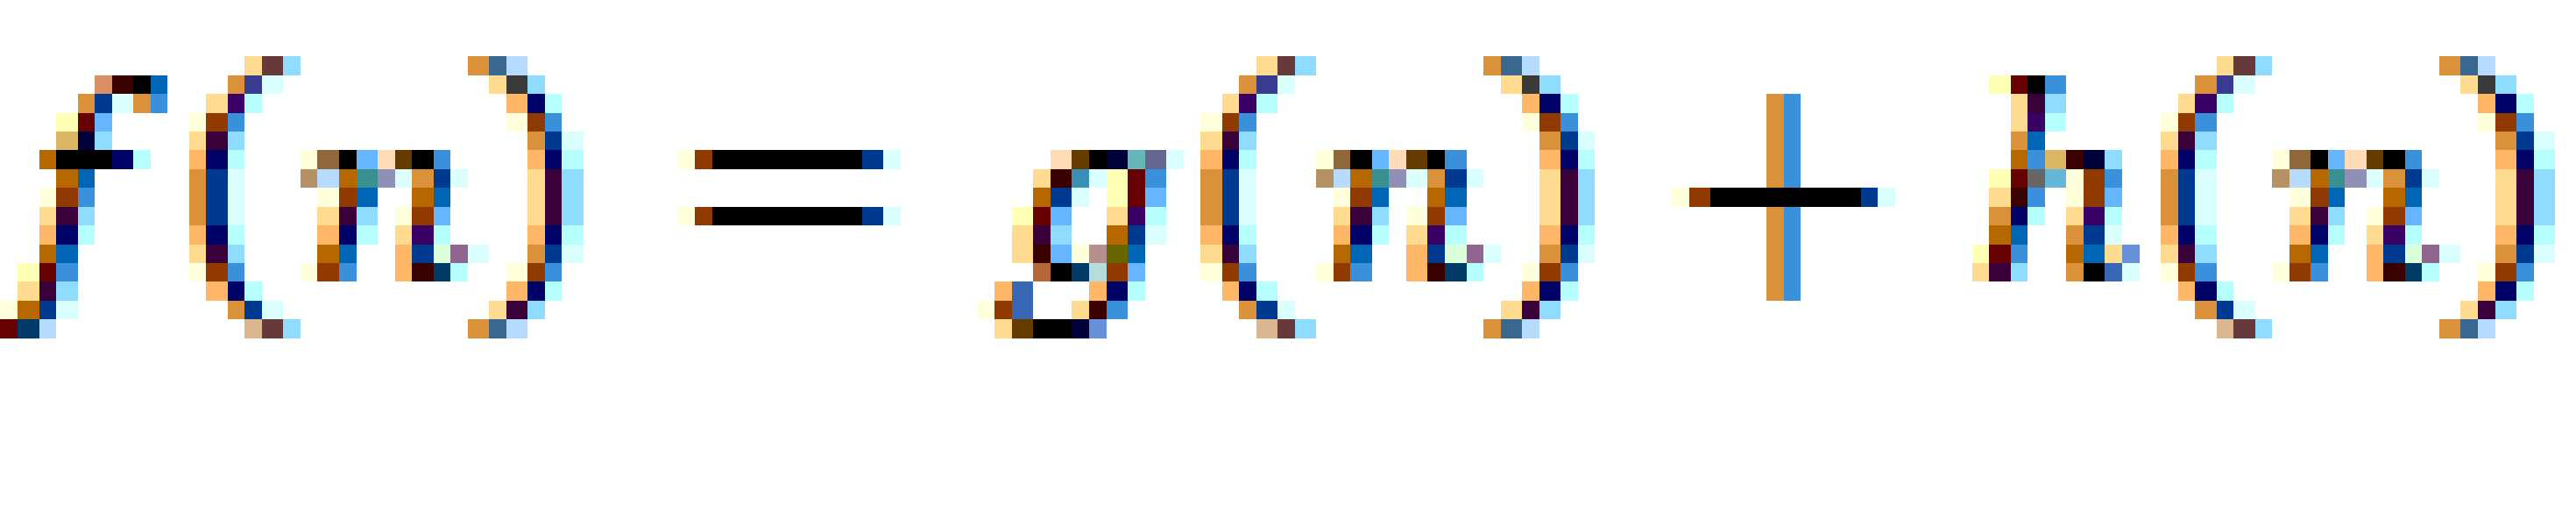
Claims (20)
- 로봇 내비게이션 시스템(robot navigation system)에 있어서,
시간에 따른(over time) 환경 내에서 이력 사람 활동 데이터(historical human activity data)를 생성하도록 구성되는 센서 네트워크;
상기 이력 사람 활동 데이터를 수신하고 상기 이력 사람 활동 데이터에 기초하는 상기 환경 내에서 복수의 위치들 사이의 경로 데이터를 도출하도록 구성되는 하나 이상의 프로세서-기반의 시스템(processor-based system)들;
상기 환경 내에서 하나 이상의 작업들을 수행하도록 구성되는 로봇을 포함하고,
상기 로봇은:
하나 이상의 센서들; 및
상기 이력 사람 활동 데이터로부터 생성되는 상기 경로 데이터를 수신하고, 각 작업에 대해 상기 경로 데이터를 사용하는 복수의 웨이포인트(waypoint)들을 생성하며, 상기 로봇으로 하여금 상기 웨이포인트들을 따라 순차적으로 이동하고 상기 웨이포인트들 일부 또는 전부에서 특정된 행위(specified action)들을 수행하게 하고, 상기 로봇에 있는(present) 상기 하나 이상의 센서들에 의해 획득되는 실시간 감지된 데이터에 응답하여 상기 로봇에 의해 상기 웨이포인트들을 따라 상기 이동에 대한 조정을 행하도록 구성되는 처리 구성요소(processing component)를 포함하는, 로봇 내비게이션 시스템. - 제1 항에 있어서,
상기 센서 네트워크는 상기 환경 내에서 사람 활동을 모니터링하기 위해 위치되는 복수의 RGB-D 카메라들을 포함하는, 로봇 내비게이션 시스템. - 제1 항에 있어서,
상기 하나 이상의 프로세서-기반의 시스템들은 네트워크에 걸쳐 상기 센서 네트워크 및 상기 로봇과 통신하는 하나 이상의 서버들을 포함하는, 로봇 내비게이션 시스템. - 제1 항에 있어서,
상기 이력 사람 활동 데이터는 적어도 1주에 걸쳐 획득되는 사람 활동 데이터를 포함하고 사람 활동의 일일 경향(daily trend)들 및 시간별 경향(hourly trend)들 중 하나 또는 둘 다를 포함하는, 로봇 내비게이션 시스템. - 제1 항에 있어서,
상기 복수의 위치들 사이의 상기 경로 데이터는 상기 환경 내에서 높은-트래픽 위치(high-traffic location)들 사이의 경로 데이터를 포함하는, 로봇 내비게이션 시스템. - 제5 항에 있어서,
상기 높은 트래픽 위치들은 계단들, 엘리베이터들, 회의실들, 로비들(lobbies), 화장실들, 또는 출입구들 중 하나 이상을 포함하는, 로봇 내비게이션 시스템. - 제1 항에 있어서,
상기 하나 이상의 프로세서-기반의 시스템들은:
상기 이력 사람 활동 데이터를 사용하여 사람 활동의 하나 이상의 표현(representation)들을 생성하고;
상기 사람 활동의 표현들에 기초하여 상기 복수의 위치들에서 사람 활동을 모델링하며;
상기 모델링된 사람 활동에 기초하여 하나 이상의 비용 맵(cost map)들을 생성하고;
상기 하나 이상의 비용 맵들을 사용하여 상기 복수의 위치들 사이의 상기 경로 데이터를 도출함으로써
상기 복수의 위치들 사이의 상기 경로 데이터를 도출하도록 구성되는, 로봇 내비게이션 시스템. - 제7 항에 있어서,
상기 사람 활동의 하나 이상의 표현들은 히트 맵(heat map)들을 포함하는, 로봇 내비게이션 시스템. - 제7 항에 있어서,
상기 복수의 위치들에서 사람 활동을 모델링하는 것은 은닉 마르코프 모델(Hidden Markov Model)들을 생성하는 것을 포함하는, 로봇 내비게이션 시스템. - 제7 항에 있어서,
상기 하나 이상의 비용 맵들은 상기 환경의 각 플로어(floor)에 대한 반응성 중요 비용 맵(reactive key cost map)을 포함하는, 로봇 내비게이션 시스템. - 제7 항에 있어서,
경로 데이터를 도출하는 것은 상기 각각의 복수의 위치들 사이의 경로들의 비용을 도출하는 것과 상기 각각의 복수의 위치들 사이의 가장 낮은 비용 경로를 식별하는 것을 포함하는, 로봇 내비게이션 시스템. - 사람들과 공유되는 환경에서 로봇을 내비게이팅하는 방법(method for navigating a robot)에 있어서,
시간에 따른 환경 내에서 이력 사람 활동 데이터를 획득하는 단계;
상기 이력 사람 활동 데이터에 기초하여 상기 환경 내에서 복수의 위치들 사이의 경로 데이터를 도출하는 단계; 및
로봇에서:
상기 이력 사람 활동 데이터로부터 생성되는 상기 경로 데이터를 수신하는 단계;
상기 경로 데이터에 기초하여 수행될 작업에 대응하는 복수의 웨이포인트들을 생성하는 단계;
상기 로봇으로 하여금 상기 웨이포인트들을 따라 순차적으로 이동하고 상기 웨이포인트들 일부 또는 전부에서 특정된 행위들을 수행하게 하는 단계;
상기 로봇에 있는 하나 이상의 센서들에 의해 획득되는 실시간 감지된 데이터에 응답하여 상기 로봇에 의해 상기 웨이포인트들을 따른 상기 이동에 대한 조정을 행하는 단계를 포함하는, 사람들과 공유되는 환경에서 로봇을 내비게이팅하는 방법. - 제12 항에 있어서,
상기 이력 사람 활동 데이터는 상기 로봇 외부의 센서 네트워크에 의해 생성되는, 사람들과 공유되는 환경에서 로봇을 내비게이팅하는 방법. - 제12 항에 있어서,
상기 이력 사람 활동 데이터는 적어도 1주일에 걸쳐 획득되는 사람 활동 데이터를 포함하고 사람 활동의 일일 경향들 및 시간별 경향들 중 하나 또는 둘 다를 포함하는, 사람들과 공유되는 환경에서 로봇을 내비게이팅하는 방법. - 제12 항에 있어서,
상기 경로 데이터는 상기 환경 내에서 높은-트래픽 위치들 사이의 경로 데이터를 포함하는, 사람들과 공유되는 환경에서 로봇을 내비게이팅하는 방법. - 제12 항에 있어서,
상기 환경 내에서 상기 복수의 위치들 사이의 경로 데이터를 도출하는 단계는:
상기 이력 사람 활동 데이터를 사용하여 사람 활동의 하나 이상의 표현들을 생성하는 단계;
상기 사람 활동의 표현들에 기초하는 상기 복수의 위치들에서 사람 활동을 모델링하는 단계;
상기 모델링되는 사람 활동에 기초하는 하나 이상의 비용 맵들을 생성하는 단계; 및
상기 하나 이상의 비용 맵들을 사용하여 상기 복수의 위치들 사이의 상기 경로 데이터를 도출하는 단계를 포함하는, 사람들과 공유되는 환경에서 로봇을 내비게이팅하는 방법. - 제12 항에 있어서,
상기 경로 데이터를 도출하는 단계는 상기 각각의 복수의 위치들 사이의 경로들의 비용을 도출하고 상기 각각의 복수의 위치들 사이의 가장 낮은 비용 경로를 식별하는 단계를 포함하는, 사람들과 공유되는 환경에서 로봇을 내비게이팅하는 방법. - 로봇에 있어서:
하나 이상의 센서들;
모터를 포함하는 구동 시스템; 및
처리 구성요소를 포함하고,
상기 처리 구성요소는:
이력 사람 활동 데이터로부터 생성되는 경로 데이터를 외부 소스로부터 수신하고;
각각의 작업에 대해, 상기 경로 데이터를 사용하여 복수의 웨이포인트들을 생성하며;
상기 로봇으로 하여금 상기 웨이포인트들을 따라 순차적으로 이동하게 하는 명령들을 상기 모터에 전달하고;
상기 로봇에 있는 상기 하나 이상의 센서들에 의해 획득되는 실시간 감지되는 데이터에 응답하여 상기 로봇에 의해 상기 웨이포인트들을 따라 상기 이동에 대한 조정을 행하도록 구성되는, 로봇. - 제18 항에 있어서,
상기 이력 사람 활동 데이터는 상기 로봇 외부의 센서 네트워크에 의해 획득되고 상기 각각의 작업이 수행되는 환경 내에 위치되는, 로봇. - 제18 항에 있어서,
상기 이력 사람 활동 데이터는 적어도 1주에 걸쳐 획득되는 사람 활동 데이터를 포함하고 사람 활동의 일일 경향들 및 시간별 경향들 중 하나 또는 둘 다를 포함하는, 로봇.
Applications Claiming Priority (3)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| US15/870,534 US10612934B2 (en) | 2018-01-12 | 2018-01-12 | System and methods for robotic autonomous motion planning and navigation |
| US15/870,534 | 2018-01-12 | ||
| PCT/US2018/056827 WO2019139659A1 (en) | 2018-01-12 | 2018-10-22 | System and methods for robotic autonomous motion planning and navigation |
Publications (2)
| Publication Number | Publication Date |
|---|---|
| KR20200099611A true KR20200099611A (ko) | 2020-08-24 |
| KR102697721B1 KR102697721B1 (ko) | 2024-08-21 |
Family
ID=67212798
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| KR1020207022386A Active KR102697721B1 (ko) | 2018-01-12 | 2018-10-22 | 로봇 자율 모션 계획 및 내비게이션을 위한 시스템 및 방법들 |
Country Status (7)
| Country | Link |
|---|---|
| US (1) | US10612934B2 (ko) |
| EP (1) | EP3738009B1 (ko) |
| JP (1) | JP7848988B2 (ko) |
| KR (1) | KR102697721B1 (ko) |
| CN (1) | CN111656296B (ko) |
| BR (1) | BR112020014097A2 (ko) |
| WO (1) | WO2019139659A1 (ko) |
Families Citing this family (24)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| US11204215B2 (en) | 2018-01-09 | 2021-12-21 | V-Armed Inc. | Wireless independent tracking system for use in firearm simulation training |
| WO2019152263A1 (en) * | 2018-01-30 | 2019-08-08 | Fisher Controls International Llc | Balanced trim regulator |
| US11099575B2 (en) * | 2018-01-30 | 2021-08-24 | Brain Corporation | Systems and methods for precise navigation of autonomous devices |
| WO2020146352A1 (en) * | 2019-01-08 | 2020-07-16 | R-Go Robotics Ltd. | System and method for monitoring movements |
| US10694053B1 (en) | 2019-01-22 | 2020-06-23 | Xerox Corporation | Wireless location tracking tag for monitoring real time location-tracking apparatus for an electronic device |
| DE112020000863T5 (de) * | 2019-02-19 | 2021-11-18 | Sony Group Corporation | Informationsverarbeitungsvorrichtung, informationsverarbeitungssystem,informationsverarbeitungsverfahren und programm |
| US11635298B2 (en) * | 2019-06-28 | 2023-04-25 | Lyft, Inc. | Systems and methods for routing decisions based on door usage data |
| US11958183B2 (en) | 2019-09-19 | 2024-04-16 | The Research Foundation For The State University Of New York | Negotiation-based human-robot collaboration via augmented reality |
| US20210197377A1 (en) | 2019-12-26 | 2021-07-01 | X Development Llc | Robot plan online adjustment |
| CN111267099B (zh) * | 2020-02-24 | 2023-02-28 | 东南大学 | 基于虚拟现实的陪护机器控制系统 |
| US20220136836A1 (en) * | 2020-11-04 | 2022-05-05 | Xerox Corporation | System and method for indoor navigation |
| US12311070B2 (en) | 2020-05-08 | 2025-05-27 | Robust AI, Inc. | Robotic social interaction |
| EP3920103B1 (en) * | 2020-06-05 | 2024-08-07 | Robert Bosch GmbH | Device and method for planning an operation of a technical system |
| DE112021003332T5 (de) * | 2020-06-23 | 2023-04-27 | Thk Co., Ltd. | System zur Verknüpfung eines autonomen Mobilroboters und autonomer Mobilroboter |
| CN112101148B (zh) * | 2020-08-28 | 2024-05-03 | 普联国际有限公司 | 一种运动目标检测方法、装置、存储介质及终端设备 |
| US20220133114A1 (en) * | 2020-11-02 | 2022-05-05 | Shiwei Liu | Autonomous Cleaning Robot |
| US12299926B2 (en) * | 2021-06-25 | 2025-05-13 | Faro Technologies, Inc. | Tracking with reference to a world coordinate system |
| US11906314B2 (en) * | 2021-09-10 | 2024-02-20 | Nec Corporation | System for waypoint selection and method of using |
| CN115123897B (zh) * | 2022-08-30 | 2023-01-06 | 深圳市海清视讯科技有限公司 | 对象检测方法、装置及设备 |
| CN117200476B (zh) * | 2023-10-16 | 2025-01-10 | 苏州玺芯人工智能科技有限公司 | 一种用于智能机器人的无线充电控制系统及方法 |
| US12416930B1 (en) | 2024-03-01 | 2025-09-16 | Robust AI, Inc. | Systems and methods for an autonomous mobile robot |
| US12436546B2 (en) | 2024-03-01 | 2025-10-07 | Robust AI, Inc. | Systems and methods for an autonomous mobile robot fleet coordination |
| US12204350B1 (en) | 2024-03-04 | 2025-01-21 | Robust AI, Inc. | Autonomous robot double drive assembly |
| CN119374595B (zh) * | 2024-10-24 | 2025-09-16 | 国网江苏省电力有限公司建设分公司 | 一种用于防坠器悬挂的无人机路径规划方法及装置 |
Citations (4)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JP2007229854A (ja) * | 2006-02-28 | 2007-09-13 | Toyota Motor Corp | 自律移動型ロボット |
| JP2010072811A (ja) * | 2008-09-17 | 2010-04-02 | Olympus Corp | 情報処理システム、プログラム及び情報記憶媒体 |
| JP2011128758A (ja) * | 2009-12-16 | 2011-06-30 | Toyota Motor Corp | 経路探索システム、方法、プログラム、並びに移動体 |
| JP2012203646A (ja) * | 2011-03-25 | 2012-10-22 | Advanced Telecommunication Research Institute International | 流れ状態判別装置、流れ状態判別方法、流れ状態判別プログラムおよびそれらを用いたロボット制御システム |
Family Cites Families (33)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| US7206753B2 (en) * | 2001-05-04 | 2007-04-17 | Axxon Robotics, Llc | Methods for facilitating a retail environment |
| US7250907B2 (en) * | 2003-06-30 | 2007-07-31 | Microsoft Corporation | System and methods for determining the location dynamics of a portable computing device |
| US7739040B2 (en) * | 2006-06-30 | 2010-06-15 | Microsoft Corporation | Computation of travel routes, durations, and plans over multiple contexts |
| US20110037619A1 (en) | 2009-08-11 | 2011-02-17 | On Time Systems, Inc. | Traffic Routing Using Intelligent Traffic Signals, GPS and Mobile Data Devices |
| JP2009175929A (ja) * | 2008-01-23 | 2009-08-06 | Toyota Central R&D Labs Inc | ドライバ状態推定装置及びプログラム |
| JP4788722B2 (ja) | 2008-02-26 | 2011-10-05 | トヨタ自動車株式会社 | 自律移動ロボット、自己位置推定方法、環境地図の生成方法、環境地図の生成装置、及び環境地図のデータ構造 |
| KR101679294B1 (ko) | 2009-08-21 | 2016-11-25 | 삼성전자주식회사 | 이동 경로의 생성, 관리 및 공유 방법과 그 장치 |
| JP5409924B2 (ja) * | 2010-09-21 | 2014-02-05 | トヨタ自動車株式会社 | 移動体 |
| JP5690113B2 (ja) * | 2010-10-22 | 2015-03-25 | 日本信号株式会社 | 自律移動サービス提供システム |
| US8364395B2 (en) * | 2010-12-14 | 2013-01-29 | International Business Machines Corporation | Human emotion metrics for navigation plans and maps |
| JP5763384B2 (ja) * | 2011-03-30 | 2015-08-12 | 株式会社国際電気通信基礎技術研究所 | 移動予測装置、ロボット制御装置、移動予測プログラムおよび移動予測方法 |
| US9205886B1 (en) | 2011-05-06 | 2015-12-08 | Google Inc. | Systems and methods for inventorying objects |
| US8761933B2 (en) * | 2011-08-02 | 2014-06-24 | Microsoft Corporation | Finding a called party |
| US9495962B2 (en) * | 2011-09-19 | 2016-11-15 | Personetics Technologies Ltd. | System and method for evaluating intent of a human partner to a dialogue between human user and computerized system |
| US20160253740A1 (en) * | 2012-12-14 | 2016-09-01 | Wal-Mart Stores, Inc. | Systems and methods for generating and using a heat map of a retail location to reduce overcrowding |
| US9709990B2 (en) | 2012-12-21 | 2017-07-18 | Toyota Jidosha Kabushiki Kaisha | Autonomous navigation through obstacles |
| WO2014170444A1 (en) * | 2013-04-17 | 2014-10-23 | Tomtom International B.V. | Methods and apparatus for providing travel information |
| CN103558856A (zh) * | 2013-11-21 | 2014-02-05 | 东南大学 | 动态环境下服务动机器人导航方法 |
| US9563205B2 (en) | 2014-02-10 | 2017-02-07 | Savioke, Inc. | Sensor configurations and methods for mobile robot |
| US9911088B2 (en) * | 2014-05-01 | 2018-03-06 | Microsoft Technology Licensing, Llc | Optimizing task recommendations in context-aware mobile crowdsourcing |
| US9452530B2 (en) | 2014-09-12 | 2016-09-27 | Toyota Jidosha Kabushiki Kaisha | Robot motion replanning based on user motion |
| SG10201405949XA (en) | 2014-09-22 | 2016-04-28 | Ctrlworks Pte Ltd | Method and apparatus for navigation of a robotic device |
| US10311400B2 (en) * | 2014-10-24 | 2019-06-04 | Fellow, Inc. | Intelligent service robot and related systems and methods |
| US9796093B2 (en) * | 2014-10-24 | 2017-10-24 | Fellow, Inc. | Customer service robot and related systems and methods |
| JP6187499B2 (ja) * | 2015-02-19 | 2017-08-30 | Jfeスチール株式会社 | 自律移動ロボットの自己位置推定方法、自律移動ロボット、及び自己位置推定用ランドマーク |
| EP3274255A4 (en) | 2015-03-26 | 2018-12-05 | Matternet, Inc. | Route planning for unmanned aerial vehicles |
| CN105241461A (zh) | 2015-11-16 | 2016-01-13 | 曾彦平 | 机器人的地图创建及定位方法和机器人系统 |
| CN109152555B (zh) * | 2016-03-18 | 2022-09-06 | 哈佛大学校长及研究员协会 | 自动分类动物行为 |
| EP4410155A1 (en) * | 2016-05-09 | 2024-08-07 | Grabango Co. | System and method for computer vision driven applications within an environment |
| WO2017197170A1 (en) * | 2016-05-12 | 2017-11-16 | The Regents Of The University Of California | Safely controlling an autonomous entity in presence of intelligent agents |
| JP6755711B2 (ja) * | 2016-05-20 | 2020-09-16 | 日本信号株式会社 | サービス提供システム |
| CN106354161A (zh) | 2016-09-26 | 2017-01-25 | 湖南晖龙股份有限公司 | 机器人运动路径规划方法 |
| US10754351B2 (en) * | 2017-02-28 | 2020-08-25 | Toyota Jidosha Kabushiki Kaisha | Observability grid-based autonomous environment search |
-
2018
- 2018-01-12 US US15/870,534 patent/US10612934B2/en active Active
- 2018-10-22 BR BR112020014097-0A patent/BR112020014097A2/pt not_active Application Discontinuation
- 2018-10-22 JP JP2020536642A patent/JP7848988B2/ja active Active
- 2018-10-22 KR KR1020207022386A patent/KR102697721B1/ko active Active
- 2018-10-22 WO PCT/US2018/056827 patent/WO2019139659A1/en not_active Ceased
- 2018-10-22 CN CN201880086093.0A patent/CN111656296B/zh active Active
- 2018-10-22 EP EP18899959.3A patent/EP3738009B1/en active Active
Patent Citations (4)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JP2007229854A (ja) * | 2006-02-28 | 2007-09-13 | Toyota Motor Corp | 自律移動型ロボット |
| JP2010072811A (ja) * | 2008-09-17 | 2010-04-02 | Olympus Corp | 情報処理システム、プログラム及び情報記憶媒体 |
| JP2011128758A (ja) * | 2009-12-16 | 2011-06-30 | Toyota Motor Corp | 経路探索システム、方法、プログラム、並びに移動体 |
| JP2012203646A (ja) * | 2011-03-25 | 2012-10-22 | Advanced Telecommunication Research Institute International | 流れ状態判別装置、流れ状態判別方法、流れ状態判別プログラムおよびそれらを用いたロボット制御システム |
Also Published As
| Publication number | Publication date |
|---|---|
| JP7848988B2 (ja) | 2026-04-21 |
| US20190219409A1 (en) | 2019-07-18 |
| KR102697721B1 (ko) | 2024-08-21 |
| CN111656296B (zh) | 2021-12-28 |
| US10612934B2 (en) | 2020-04-07 |
| BR112020014097A2 (pt) | 2020-12-01 |
| WO2019139659A1 (en) | 2019-07-18 |
| EP3738009A1 (en) | 2020-11-18 |
| JP2021510433A (ja) | 2021-04-22 |
| EP3738009B1 (en) | 2023-12-06 |
| CN111656296A (zh) | 2020-09-11 |
| EP3738009A4 (en) | 2021-07-14 |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| KR102697721B1 (ko) | 로봇 자율 모션 계획 및 내비게이션을 위한 시스템 및 방법들 | |
| US10845821B2 (en) | Route planning for a mobile robot using configuration-based preferences | |
| EP2952993B1 (en) | Method for building a map of probability of one of absence and presence of obstacles for an autonomous robot | |
| Schneier et al. | Literature review of mobile robots for manufacturing | |
| CN105425795B (zh) | 规划最优跟随路径的方法及装置 | |
| US20190054631A1 (en) | System and method for operating and controlling a hyper configurable humanoid robot to perform multiple applications in various work environments | |
| JP7581673B2 (ja) | 移動ロボットおよび移動ロボットの制御プログラム | |
| Tiwari et al. | Intelligent planning for mobile robotics: algorithmic approaches: algorithmic approaches | |
| Dhanush et al. | An omni-directional self driving robot for indoor surveillance | |
| Chow et al. | Learning human navigational skill for smart wheelchair in a static cluttered route | |
| Siswoyo et al. | Development Of an Autonomous Robot To Guide Visitors In Health Facilities Using A Heskylens Camera: Development Of an Autonomous Robot To Guide Visitors In Health Facilities Using A Heskylens Camera | |
| Tang et al. | Development of a navigation system for semi-autonomous operation of wheelchairs | |
| WO2022153669A1 (ja) | 分散協調システム、及びタスク実行方法 | |
| Sogo et al. | Mobile robot navigation by a distributed vision system | |
| Sakr et al. | Development of an Advanced Medical Assistance Robot with Intelligent Guidance | |
| Paolini et al. | A web-based user interface for a mobile robotic system | |
| Casuccio | ROS2-Based AMR System for Mapping and Navigation in Unknown Indoor Environments | |
| Dharmawan et al. | Design innovation of mesoscale robotic swarms: applications to cooperative urban sensing and mapping | |
| Acosta-Amaya et al. | Map-Bot: Mapping Model of Indoor Work Environments in Mobile Robotics | |
| Greynoon et al. | AMR For Luggage Delivery Robot with Navigation Using Lidar and 3D Camera | |
| León et al. | Multi-robot slam and map merging | |
| Petitti et al. | A Distributed Cooperative Architecture for Robotic Networks with Application to Ambient Intelligence | |
| Neto | AI-Enhanced Indoor Localization System for Autonomous Mobile Robots | |
| Paolini et al. | A web-based mobile robotic system for control and sensor fusion studies | |
| Lauria et al. | Two Aspects of Multiple Mobile |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| PA0105 | International application |
St.27 status event code: A-0-1-A10-A15-nap-PA0105 |
|
| PG1501 | Laying open of application |
St.27 status event code: A-1-1-Q10-Q12-nap-PG1501 |
|
| A201 | Request for examination | ||
| PA0201 | Request for examination |
St.27 status event code: A-1-2-D10-D11-exm-PA0201 |
|
| D13-X000 | Search requested |
St.27 status event code: A-1-2-D10-D13-srh-X000 |
|
| D14-X000 | Search report completed |
St.27 status event code: A-1-2-D10-D14-srh-X000 |
|
| R17-X000 | Change to representative recorded |
St.27 status event code: A-3-3-R10-R17-oth-X000 |
|
| E902 | Notification of reason for refusal | ||
| PE0902 | Notice of grounds for rejection |
St.27 status event code: A-1-2-D10-D21-exm-PE0902 |
|
| E13-X000 | Pre-grant limitation requested |
St.27 status event code: A-2-3-E10-E13-lim-X000 |
|
| P11-X000 | Amendment of application requested |
St.27 status event code: A-2-2-P10-P11-nap-X000 |
|
| P13-X000 | Application amended |
St.27 status event code: A-2-2-P10-P13-nap-X000 |
|
| P22-X000 | Classification modified |
St.27 status event code: A-2-2-P10-P22-nap-X000 |
|
| E701 | Decision to grant or registration of patent right | ||
| PE0701 | Decision of registration |
St.27 status event code: A-1-2-D10-D22-exm-PE0701 |
|
| GRNT | Written decision to grant | ||
| PR0701 | Registration of establishment |
St.27 status event code: A-2-4-F10-F11-exm-PR0701 |
|
| PR1002 | Payment of registration fee |
St.27 status event code: A-2-2-U10-U12-oth-PR1002 Fee payment year number: 1 |
|
| PG1601 | Publication of registration |
St.27 status event code: A-4-4-Q10-Q13-nap-PG1601 |
|
| R18 | Changes to party contact information recorded |
Free format text: ST27 STATUS EVENT CODE: A-5-5-R10-R18-OTH-X000 (AS PROVIDED BY THE NATIONAL OFFICE) |
|
| R18-X000 | Changes to party contact information recorded |
St.27 status event code: A-5-5-R10-R18-oth-X000 |
|
| P22-X000 | Classification modified |
St.27 status event code: A-4-4-P10-P22-nap-X000 |