WO2007145327A1 - 遠隔操作システム - Google Patents
遠隔操作システム Download PDFInfo
- Publication number
- WO2007145327A1 WO2007145327A1 PCT/JP2007/062147 JP2007062147W WO2007145327A1 WO 2007145327 A1 WO2007145327 A1 WO 2007145327A1 JP 2007062147 W JP2007062147 W JP 2007062147W WO 2007145327 A1 WO2007145327 A1 WO 2007145327A1
- Authority
- WO
- WIPO (PCT)
- Prior art keywords
- tool
- unit
- distance
- operation tool
- remote
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Ceased
Links
Classifications
-
- A—HUMAN NECESSITIES
- A61—MEDICAL OR VETERINARY SCIENCE; HYGIENE
- A61B—DIAGNOSIS; SURGERY; IDENTIFICATION
- A61B34/00—Computer-aided surgery; Manipulators or robots specially adapted for use in surgery
- A61B34/70—Manipulators specially adapted for use in surgery
-
- A—HUMAN NECESSITIES
- A61—MEDICAL OR VETERINARY SCIENCE; HYGIENE
- A61B—DIAGNOSIS; SURGERY; IDENTIFICATION
- A61B90/00—Instruments, implements or accessories specially adapted for surgery or diagnosis and not covered by any of the groups A61B1/00 - A61B50/00, e.g. for luxation treatment or for protecting wound edges
- A61B90/30—Devices for illuminating a surgical field, the devices having an interrelation with other surgical devices or with a surgical procedure
-
- A—HUMAN NECESSITIES
- A61—MEDICAL OR VETERINARY SCIENCE; HYGIENE
- A61B—DIAGNOSIS; SURGERY; IDENTIFICATION
- A61B17/00—Surgical instruments, devices or methods
- A61B2017/00017—Electrical control of surgical instruments
- A61B2017/00212—Electrical control of surgical instruments using remote controls
-
- A—HUMAN NECESSITIES
- A61—MEDICAL OR VETERINARY SCIENCE; HYGIENE
- A61B—DIAGNOSIS; SURGERY; IDENTIFICATION
- A61B34/00—Computer-aided surgery; Manipulators or robots specially adapted for use in surgery
- A61B34/30—Surgical robots
- A61B2034/301—Surgical robots for introducing or steering flexible instruments inserted into the body, e.g. catheters or endoscopes
-
- A—HUMAN NECESSITIES
- A61—MEDICAL OR VETERINARY SCIENCE; HYGIENE
- A61B—DIAGNOSIS; SURGERY; IDENTIFICATION
- A61B90/00—Instruments, implements or accessories specially adapted for surgery or diagnosis and not covered by any of the groups A61B1/00 - A61B50/00, e.g. for luxation treatment or for protecting wound edges
- A61B90/06—Measuring instruments not otherwise provided for
- A61B2090/061—Measuring instruments not otherwise provided for for measuring dimensions, e.g. length
-
- A—HUMAN NECESSITIES
- A61—MEDICAL OR VETERINARY SCIENCE; HYGIENE
- A61B—DIAGNOSIS; SURGERY; IDENTIFICATION
- A61B90/00—Instruments, implements or accessories specially adapted for surgery or diagnosis and not covered by any of the groups A61B1/00 - A61B50/00, e.g. for luxation treatment or for protecting wound edges
- A61B90/36—Image-producing devices or illumination devices not otherwise provided for
- A61B90/361—Image-producing devices, e.g. surgical cameras
- A61B2090/3614—Image-producing devices, e.g. surgical cameras using optical fibre
-
- A—HUMAN NECESSITIES
- A61—MEDICAL OR VETERINARY SCIENCE; HYGIENE
- A61B—DIAGNOSIS; SURGERY; IDENTIFICATION
- A61B34/00—Computer-aided surgery; Manipulators or robots specially adapted for use in surgery
- A61B34/30—Surgical robots
Definitions
- the present invention relates to a remote control system for performing an operation on an object in a space beyond a partition wall.
- This remote control system can be suitably applied to a surgical system that can minimize the invasion to the human body and perform the surgery accurately.
- Patent Document 1 discloses a system for driving a manipulator incorporating an endoscope. In this system, the operation of the manager is performed via a control stick or a voice recognition device.
- Patent Document 2 discloses a point lock system in which a rod-shaped manipulator is operated with an insertion hole in a body wall as a fulcrum in order to minimize invasion to a patient.
- the operator wears a face-mounted display (FMD) and operates the operation input device while driving the treatment manipulator while watching the image displayed there.
- the observation manipulator detects the movement of the doctor's head by a 3D digitizer provided in the FMD, and its movement and position are controlled accordingly.
- Patent Document 3 discloses a system in which a manipulator is supported on a manipulator support mechanism in order to reduce the burden on an operator. Therefore, in this system, the operator -Operate the filter directly. Endoscopy images are viewed on the external screen.
- Non-Patent Document 1 three light emitting points are provided on the side surface of the surgical instrument tip, and based on the images of the three points, the internal irradiation point (laser spot) of the laser beam that is also irradiated with the distal force of the surgical instrument ) And the surgical tool tip, and a method of controlling the surgical tool so that the distance becomes a predetermined value is disclosed.
- Patent Document 1 Japanese Patent Laid-Open No. 06-030896
- Patent Document 2 Japanese Patent Laid-Open No. 08-215205
- Patent Document 3 Japanese Patent Laid-Open No. 2003-052716
- Non-patent document 1 Autonomous Instruments ⁇ ⁇ Positioning of surgical Instruments in Robotized L aparoscopic Surgery Using Visual Servoing ”, A. Krupa, et al., IEEE Trans, on Robotics and Automation, Vol. 19 (2003), No. 5 , pp. 842-853
- the manipulator is operated either directly by an operator (operator or doctor) (Patent Document 3) or by using an operation input device (Patent Document 2).
- the image of the surgical site by an endoscope is viewed on an external screen (Patent Documents 1 and 3), or on an FMD or HMD (Head Mounted Display) (Patent Document 2).
- Non-Patent Document 1 the surface force of the target organ is adjusted to bring it closer to a predetermined distance. After that, it is expected that the operator will operate the surgical tool manually or using the operation input device while looking at the external screen.
- performing an operation on an object without visually observing the object is also performed by a remote operation device other than the surgical device.
- a remote operation device other than the surgical device.
- the object is stored in a container that excludes the object, and the tool used for processing is also remotely controlled by the external force of the container Sometimes.
- the operator and the object are separated by a partition such as a container, and the operator cannot sufficiently confirm the object visually, the same problem as that of the above-described surgical apparatus Can occur.
- the target object is too small to be confirmed with the naked eye, or when the operator is performing a fine calorie that cannot be confirmed with the naked eye. A similar problem can occur.
- the problem to be solved by the present invention is to provide a remote operation system such as a surgical system that can perform natural operation by bringing the visual recognition position and the operation position as close as possible to each other and can perform an accurate operation. It is to be.
- a remote operation system which has been made to solve the above-mentioned problems, is a remote operation system for performing an operation on an object.
- an operating tool having a spot light irradiating unit for irradiating the object at the tip;
- an external display unit for displaying images taken by the photographing tool
- An input unit for an operator to indicate a position corresponding to the display on the external display unit
- a distance calculation unit for calculating a distance between the position instructed via the D input unit and the position of the spot light irradiated on the object by the spot light irradiation unit;
- control unit that controls the drive unit based on the distance so that the tip of the operation tool approaches the indicated position
- the control unit moves the surgical instrument so that the distance becomes smaller, and the distance is a predetermined value. After the following, it may have a function of controlling the drive unit so that the distal end of the surgical instrument approaches the designated position.
- the remote operation system according to the present invention can be suitably used when an operation is performed on an object in a space beyond the partition wall.
- a remote control system includes: a) a photographing tool for photographing the object;
- an external display unit for displaying images taken by the photographing tool
- An input unit for an operator to indicate a position corresponding to the display on the external display unit
- a distance calculation unit for calculating a distance between the position instructed via the D input unit and the position of the spot light irradiated on the object by the spot light irradiation unit;
- control unit that controls the drive unit based on the distance so that the tip of the operation tool approaches the indicated position
- the operating tool is rotated around the single hole so that the distance becomes small, and the operating tool is moved in the axial direction after the distance becomes a predetermined value or less. Let's have it.
- the control unit may have a function of controlling the drive unit so that the state where the distance is equal to or less than a predetermined value is maintained when the indicated position is moved.
- a function can be used with or without a partition wall.
- the remote operation system according to the present invention can be used as a surgical system by using the operation tool as a surgical tool.
- the object corresponds to an affected area of a patient.
- the septum corresponds to the patient's body wall.
- the operator is outside. While observing the screen of the unit display unit, the control unit uses the input unit to indicate the position corresponding to the display on the screen, so that the control unit emits the spot light irradiation point and the indication point generated by the operating tool (surgical tool) tip force. Control to reduce the distance of. For this reason, the operator only has to see the screen of the external display unit.
- the external display unit can be viewed by anyone other than the operator. In addition to the external display unit, the operator can appropriately determine the surrounding situation and perform an appropriate team play by appropriately viewing the surrounding situation.
- the operator can power the operation tool (surgical tool) as desired by the functions of the control unit and the drive unit.
- the operability of the remote operation system of the present invention will be described while comparing with a conventional operation system.
- the result of operating with the operation input device only appears on the screen as the movement of the surgical tool.
- the result of the operation using the input unit also appears on the screen.
- the result will be the movement of the surgical instrument as it is, and thus careful operation is required. Since both the target point (instruction point) and the actual position are displayed on the screen, if the actual movement of the surgical tool is inappropriate, the target point (instructed point) can be changed to take appropriate action. Can be performed.
- the present invention is not limited to the case where the operator operates near the object, but can also be applied to the case where the operator is located far away from the object.
- at least the external display unit and the input unit are disposed on the operator side (operator side device), and the photographing tool, the operation tool, and the drive unit are disposed on the object side (object side device).
- the distance calculation unit and the control unit may be provided in either the operator side device or the object side device.
- the operator side device and the object side device are connected using a communication line such as a LAN or the Internet. Through this communication line, imaging data from the imaging tool is transmitted to the external display unit, and input information from the input unit is transmitted to the driving unit (through the control unit and the distance calculation unit).
- a communication line such as a LAN or the Internet.
- FIG. 1 is a schematic configuration diagram of a surgical system according to a first embodiment of the present invention.
- FIG. 2 is a schematic configuration diagram of a surgical system according to a second embodiment of the present invention.
- FIG. 3 is a schematic configuration diagram showing a relationship between a tool and a surgical object in one embodiment of the present invention.
- FIG. 4 is an explanatory view showing a method of driving a tool in the embodiment.
- FIG. 5 is an explanatory view showing another method of driving the tool in the embodiment.
- FIG. 1 shows a surgical system which is a first embodiment of a remote control system according to the present invention.
- This system includes a rod-like surgical tool (operation tool) 11, a photographing tool 12, a drive unit 13, an imaging unit 14, a control unit 15, an external display unit 16, an input unit 17, and the like.
- the input unit includes a touch panel 17a attached on the screen of the external display unit, a mouse 17b connected to the control unit, and a keyboard (not shown).
- the surgical tool 11 and the imaging tool 12 are respectively inserted into the body cavity of the patient 18 through a single hole 19, and the surgical tool 11 is given movement such as rotation and advance / retreat by the drive unit 13.
- the movement of the photographic tool 12 is controlled by the imaging unit 14, and
- the shadowed video is signaled by the imaging unit 14 and sent to the control unit 15.
- the control unit 15 displays the video imaged by the imaging tool 12 on the external display unit 16, and uses the drive unit 13 to move and process the surgical tool 11 based on the operator's instruction via the input unit 17.
- the treatment with the surgical tool 11 is, for example, laser irradiation, excision, cutting, cauterization, etc. when the surgical tool 11 is a laser knife, and excision and cutting when the surgical tool 11 is an electric knife. , Shochu, etc.
- the control unit 15 causes the surgical instrument 11 to execute the process via the drive unit 13.
- the practitioner can perform a desired operation only by giving instructions on the screen 16 while viewing the screen 16.
- FIG. 1 A second embodiment of the remote control system according to the present invention is shown in FIG.
- the present embodiment is configured as follows so that it can be used when the practitioner is at a place far away from the patient force.
- a surgical instrument 11, an imaging tool 12, a drive unit 13, an imaging unit 14, and a patient side control unit 15A similar to those of the first embodiment are arranged as a patient side device 21.
- an external display unit 16 and an input unit 17 similar to those of the first embodiment and a practitioner side control unit 15B for controlling them are arranged as a practitioner side device 22.
- the patient side device 21 and the practitioner side device 22 are connected via the Internet 23.
- the system of the second embodiment has the same configuration as the system of the first embodiment except that a communication line (LAN, Internet, etc.) is used for information transmission.
- a communication line LAN, Internet, etc.
- the operation of is the same as that of the first embodiment. Therefore, the practitioner can operate on a patient in a remote place with the same feeling as when the patient is nearby.
- the force described so far by taking the surgical system as an example can of course be applied to a remote control system other than the surgical system.
- a remote control system other than the surgical system.
- the object is stored in a container from which the object has been removed, and then the container of the present invention is used. It is possible to remotely control the tool with external force.
- the cost can be reduced as compared with the case of using a clean room that requires a large amount of cost for construction, maintenance, and operation.
- the remote control system according to the present invention can be suitably used.
- the object or processed part is not displayed on the external display.
- the operator can precisely instruct the movement of the operation tool from the input unit, thereby enabling precise machining.
- FIGS. 1 and 2 A specific embodiment of the present invention will be described with reference to FIGS.
- the basic configuration of the system of this example is the same as the surgical system of the first and second embodiments.
- the control method will be explained step by step.
- the surgical tool is referred to as a tool
- the driving unit is referred to as a robot
- the photographing tool is referred to as an endoscope
- the external display unit is referred to as a display.
- the tool 11 is gripped and controlled by the robot. As described above, the tool 11 is inserted into the single hole drilled in the body surface (Fig. 3), and is therefore subjected to kinematic constraints due to its insertion point A.
- the kinematic freedom is 4 as follows.
- the robot that controls the tool 11 need only have four joints.
- the Jacobian behavior varies depending on the camera (endoscope) parameters, the positional relationship between the camera (endoscope) 12 and the tool 11, and the distance between the tool 11 and the target (laser spot point). Force
- J since it is possible to control with almost fixing, it becomes possible to fix J by a prior calibration. That is, calibrate in advance how the laser spot P (x, y) changes when the robot (tool) rotation speed ( ⁇ , ⁇ ) is changed.
- the laser spot P (x, y) may be powered at the image speed of for that purpose
- the laser spot point P (x, y) is detected by image processing.
- the tool is inserted into the body at a speed proportional to, i.e. k -d (where k> 0).
- the program for controlling the tool (robot) as described above can be composed of the following elements.
- User interface such as program for detecting target point, calibration process, switching of online control process, setting of each parameter (all set by touch panel)
- the kinematic freedom of the tool is 4 Analysis can be performed with a degree of 5 or more, and the tool can be operated based on the result.
- the number of robot joints is set to 4 in accordance with the kinematic degree of freedom under the above conditions, but the number of robot joints or tool joints or the total number of both may be 5 or more. Of course it is possible.
Landscapes
- Health & Medical Sciences (AREA)
- Surgery (AREA)
- Life Sciences & Earth Sciences (AREA)
- Engineering & Computer Science (AREA)
- Medical Informatics (AREA)
- Biomedical Technology (AREA)
- Heart & Thoracic Surgery (AREA)
- Nuclear Medicine, Radiotherapy & Molecular Imaging (AREA)
- Molecular Biology (AREA)
- Animal Behavior & Ethology (AREA)
- General Health & Medical Sciences (AREA)
- Public Health (AREA)
- Veterinary Medicine (AREA)
- Robotics (AREA)
- Oral & Maxillofacial Surgery (AREA)
- Pathology (AREA)
- Manipulator (AREA)
Abstract
本発明の課題は、視認箇所と操作箇所をできるだけ近づけて自然な動作を可能とし、しかも正確な施術を行うことのできる遠隔操作システムを提供することにある。本発明の遠隔操作システムは、a)前記対象物を撮影する撮影具12と、b) 前記対象物を照射するスポット光照射部を先端に有する操作具11と、c)前記操作具11の位置を変化させる駆動部13と、d)撮影具12により撮影された映像を表示する外部表示部16と、e)操作者が、外部表示部の表示に対応した位置を指示するための入力部17と、f) 入力部17を介して指示された位置と、前記スポット光照射部により前記対象物に照射されたスポット光の位置の間の距離を計算する距離計算部と、g)前記距離に基づき、操作具11先端が前記指示位置に近づくように駆動部13を制御する制御部15と、を備える。
Description
明 細 書
遠隔操作システム
技術分野
[0001] 本発明は、隔壁の向こう側の空間内にある対象物に対して操作を行う遠隔操作シ ステムに関する。この遠隔操作システムは、人体への侵襲をできるかぎり少なくし、し 力も正確に手術を行うことのできる手術システムに好適に適用することができる。 背景技術
[0002] 人に対する外科的治療 (手術)においては、長い間、医師が目で見ながら、メス等 の術具を手で操作して対象箇所の開創、切除等の処置を行って ヽた。
[0003] しかし、対象器官等に関する生物学的及び解剖学的情報の蓄積及び医療技術の 向上に伴い、手術対象が小範囲且つ微細となってきた。一方、電子技術の進歩に伴 い撮像システムも小型化、高精細化が進み、色再現性の点でも医療現場での使用に 十分堪えうるようになつてきた。その結果、外科手術においても光ファイバを用いて体 内を撮影し、それを大画面に投影しつつ、医師がその画面を見ながら術具を操作す ると ヽぅ内視鏡手術も近年広く行われるようになってきた。
[0004] 更には、術具の操作についても、マニピュレータにより遠隔的に行うことが模索され 、各種の具体的方法が提案されている。例えば、特許文献 1には、内視鏡を組み込 んだマニピュレータを駆動するシステムが開示されている。このシステムでは、マ-ピ ユレータの操作は、制御用スティック又は音声認識装置を介して行われる。
[0005] 特許文献 2には、患者への侵襲を最小限に抑えるため、棒状のマニピュレータを、 体壁の挿入孔を支点として動作させるポイントロックシステムが開示されて 、る。この システムでは、操作者がフェイスマウンテッドディスプレイ (FMD)を装着し、そこに映し 出される映像を見ながら操作入力装置を操作して処置用マニピュレータを駆動する。 また、観察用マニピュレータは、医師の頭部の動きを FMDに設けられた 3次元デジタ ィザが検出し、それにより動き及び位置が制御される。
[0006] 特許文献 3には、操作者の負担を軽減するため、マニピュレータの支持機構に工 夫をカ卩えたシステムが開示されている。従って、このシステムにおいては操作者はマ
-ピユレータを直接操作する。なお、内視鏡映像は外部画面で見るようになつている
[0007] 非特許文献 1には、手術具先端の側面に 3点の発光点を設け、その 3点の映像に 基づいて、手術具の先端力も照射されるレーザ光の体内照射点(レーザスポット)と 手術具先端の間の距離を測定し、その距離が所定値となるように手術具を制御する 方法が開示されている。
[0008] 特許文献 1:特開平 06-030896号公報
特許文献 2:特開平 08-215205号公報
特許文献 3:特開 2003-052716号公報
非特干文献 1: Autonomous ό~Ό Positioning of surgical Instruments in Robotized L aparoscopic Surgery Using Visual Servoing", A. Krupa, et al., IEEE Trans, on Robot ics and Automation, Vol. 19 (2003), No. 5, pp. 842 - 853
発明の開示
発明が解決しょうとする課題
[0009] 以上説明した通り、従来の手術システムでは 、ずれもマニピュレータの操作は、操 作者 (施術者、医師)が直接行う (特許文献 3)か、操作入力装置を用いて行う (特許 文献 2)ようになつている。一方、内視鏡による術部の映像は、外部画面で見る(特 許文献 1、 3)か、或いは FMD又は HMD (ヘッドマウンテッドディスプレイ)で見るように なっている(特許文献 2)。
[0010] し力し、 FMDや HMDを装着すると、周囲の状況が全く或いは不完全にしか視認で きない。通常、手術は複数人でチームを組んで行うことが多いが、施術者(医師)が 周囲の状況を十分に把握していないとチームメンバー間の意思疎通が不十分となり 、スムーズな手術遂行が困難となる。
[0011] 一方、外部画面を見ながら操作入力装置を操作するという動作は、従来から行わ れて 、た目視しつつ術具を操作すると!/、う動作と比べると、視認箇所と操作箇所が異 なるという点で不自然なものであり、十分に細かい動作を行うことができないという欠 点がめった。
[0012] 非特許文献 1では、手術具を対象臓器の表面力 所定の距離に近づけるまでのプ
口セスが扱われ、それ以降は操作者が外部画面を見ながら手動で又は操作入力装 置を用いて手術具を操作して手術を行うことが予定されて ヽる。
[0013] また、上述のように対象物を目視せずにその対象物に対して操作を行うことは、手 術装置以外の遠隔操作装置においても行われる。例えば、酸素、水、埃等を排除し た環境下で対象物の加工を行う必要がある場合、それらを排除した容器内に対象物 を収容し、加工に用いる工具を容器外力も遠隔操作することがある。このように、容器 などの隔壁により操作者と対象物が隔てられており、それにより操作者が対象物を目 視で十分に確認することができない場合には、上述の手術装置と同様の問題が発生 しうる。また、操作者が対象物から遠い場所に居る場合、対象物が肉眼では確認する ことができな 、ほど小さ 、場合、あるいは肉眼では確認することができな 、微細なカロ ェを行う場合などにも同様の問題が発生しうる。
[0014] そこで本発明が解決しょうとする課題は、視認箇所と操作箇所をできるだけ近づけ て自然な動作を可能とし、し力も正確な操作を行うことができる手術システムなどの遠 隔操作システムを提供することである。
課題を解決するための手段
[0015] 上記課題を解決するために成された本発明に係る遠隔操作システムは、対象物に 対して操作を行う遠隔操作システムにお 、て、
a)前記対象物を撮影する撮影具と、
b)前記対象物を照射するスポット光照射部を先端に有する操作具と、
c)前記操作具の位置を変化させる駆動部と、
d)前記撮影具により撮影された映像を表示する外部表示部と、
e)操作者が、外部表示部の表示に対応した位置を指示するための入力部と、
D入力部を介して指示された位置と、前記スポット光照射部により前記対象物に照 射されたスポット光の位置の間の距離を計算する距離計算部と、
g)前記距離に基づき、操作具先端が前記指示位置に近づくように駆動部を制御す る制御部と、
を備えることを特徴とする。
[0016] 前記制御部は、前記距離が小さくなるように手術具を移動させ、前記距離が所定値
以下になった後に、手術具の先端を指示位置に近づけるように駆動部を制御する機 能を有するようにしてもよい。
[0017] 本発明に係る遠隔操作システムは、隔壁の向こう側の空間内にある対象物に対し て操作を行う場合に好適に用いることができる。そのような遠隔操作システムは、 a)前記対象物を撮影する撮影具と、
b)前記隔壁に設けられた単孔を通して前記空間に挿入される、先端にスポット光 照射部を有する棒状の操作具と、
c)前記操作具の位置を変化させる駆動部と、
d)撮影具により撮影された映像を表示する外部表示部と、
e)操作者が、外部表示部の表示に対応した位置を指示するための入力部と、
D入力部を介して指示された位置と、前記スポット光照射部により前記対象物に照 射されたスポット光の位置の間の距離を計算する距離計算部と、
g)前記距離に基づき、操作具先端が前記指示位置に近づくように駆動部を制御す る制御部と、
を備えることを特徴とする。
[0018] 前記隔壁がある場合において、前記制御部は、
まず前記距離が小さくなるように操作具を前記単孔を中心として回動させ、 前記距離が所定値以下になった後に、操作具をその軸方向に移動させる、 ように駆動部を制御する機能を有するようにしてもょ 、。
[0019] 前記制御部は、前記指示位置が移動したときに前記距離が所定値以下である状態 が維持されるように前記駆動部を制御する機能を有するようにしてもょ 、。このような 機能は隔壁の有無に関わらず用いることができる。
[0020] 本発明に係る遠隔操作システムは、前記操作具を手術具とすることにより、手術シ ステムとして用いることができる。この場合、前記対象物は患者の患部に該当する。ま た、隔壁がある場合に用いるシステムにおいては、前記隔壁は患者の体壁に該当す る。
発明の効果
[0021] 本発明に係る遠隔操作システム (手術システムを含む)では、操作者 (施術者)は外
部表示部の画面を見ながら、入力部を用いてその画面の表示に対応した位置を指 示することにより、制御部が操作具 (手術具)先端力 発せられるスポット光照射点と 指示点との距離を近づけるように制御を行う。このため、操作者が見なければならな いのは外部表示部の画面だけとなる。外部表示部は、操作者以外の者も見ることが できる。また、操作者は外部表示部以外に周囲の状況を適宜見ることにより、周囲の 状況を判断して適切なチームプレイを行うことができる。
[0022] 操作者は、入力部を用いて操作を行うことにより、制御部及び駆動部の働きにより 操作具 (手術具)を意のままに動力せることができる。
以下、手術システムを例として、従来の手術システムと比較しつつ、本発明の遠隔 操作システムの操作性の良い点を説明する。従来の手術システムでは、操作入力装 置で操作した結果は手術具の動きとして画面に現れるだけであるが、本発明では、 それに加えて、入力部を用いた操作の結果も画面上に現れる。従来の手術システム では、施術者が操作入力部で入力を行うと、その結果がそのまま手術具の動きとなつ てしまうため、慎重な操作が必要であつたが、本発明では手術具の動きの目標点 (指 示点)と実際の位置の双方が画面上に表示されるため、手術具の実際の動きが不適 切な場合には、目標点 (指示点)を変更することにより、適切な対応を行うことができる ようになる。
[0023] 本発明は、操作者が対象物の近くで操作をする場合に限らず、操作者が対象物か ら遠く離れた場所にいる場合にも適用することができる。その場合、少なくとも外部表 示部及び入力部は操作者側に配置し (操作者側装置)、撮影具、操作具及び駆動 部は対象物側に配置する (対象物側装置)。距離計算部及び制御部は操作者側装 置、対象物側装置のいずれに設けてもよい。そして、操作者側装置と対象物側装置 を LANやインターネットなどの通信回線を用いて接続する。この通信回線を通して、 撮影具からの撮影データを外部表示部へ、また、入力部からの入力情報を (制御部 、距離計算部を通して)駆動部へ伝達する。これにより、操作者は対象物の近くで操 作をするのと同じ感覚で、遠く離れた場所にある対象物に対して操作をすることがで きる。
図面の簡単な説明
[0024] [図 1]本発明の第 1実施形態である手術システムの概略構成図。
[図 2]本発明の第 2実施形態である手術システムの概略構成図。
[図 3]本発明の一実施例におけるツールと手術対象の関係を示す概略構成図。
[図 4]上記実施例におけるツール駆動の方法を示す説明図。
[図 5]上記実施例におけるツール駆動の別の方法を示す説明図。
符号の説明
[0025] 11…手術具 (ツール)
12…撮影具 (内視鏡)
13…駆動部
14· · ·撮像部
15…制御部
16· · ·外部表示部
17…入力部
17a…タツチパネル
17b…マウス
18…患者
19· · ·手術具挿入単孔
21…患者側装置
22…施術者側装置
23…インターネット
発明を実施するための最良の形態
[0026] 本発明に係る遠隔操作システムの第 1の実施形態である手術システムを図 1に示す 。本システムは、棒状の手術具 (操作具) 11、撮影具 12、駆動部 13、撮像部 14、制 御部 15、外部表示部 16、入力部 17等を備えている。本システムでは、入力部は、外 部表示部の画面上に取り付けられたタツチパネル 17aと、制御部に接続されたマウス 17b、及び図示せぬキーボード等力 成る。手術具 11と撮影具 12は患者 18の体腔 にそれぞれ単孔 19を介して挿入され、手術具 11は駆動部 13により回動、進退移動 等の動きが付与される。撮影具 12は撮像部 14によりその動きが制御され、また、撮
影した映像は撮像部 14で信号ィ匕され、制御部 15に送られる。制御部 15は、撮影具 12で撮影された映像を外部表示部 16に表示するとともに、入力部 17を介した施術 者の指示に基づき、駆動部 13を用いて手術具 11の動き及び処理を制御する。手術 具 11による処理とは、例えば手術具 11がレーザーメスである場合には、レーザーに よる照射、切除、切断、焼灼等であり、手術具 11が電気メスである場合には切除、切 断、焼灼等である。
[0027] このシステムの動作の一例は次の通りである。施術者が撮影具 12を体内に挿入す ると、その映像が外部表示部 16に表示される。その状態で手術具 11を体内に挿入 し、駆動部 13をセットすることにより、駆動部 13による手術具 11の駆動を可能とする 。外部表示部 16の画面を見ながら施術者が画面上のタツチパネル 17aで目標点を 指示すると、制御部 15は画面上で、指示された目標点と手術具 11の先端点との位 置の差を検出し、手術具 11の先端が目標点に近づくように、手術具 11の動きを計算 する。計算結果は駆動部 13に送られ、駆動部 13はそれに従って手術具 11の動きを 制御する。この制御により手術具 11の先端点が目標点に近づき、一致すると、施術 者は手術具 11に対して、タツチパネル 17a上で必要な処理を指示する。この指示を 受けた制御部 15は、駆動部 13を介して手術具 11にその処理を実行させる。こうして 、施術者は、画面 16を見ながら、画面 16上で指示をするだけで、所望の手術を行う ことができる。
[0028] なお、ここでは入力部 17としてタツチパネル 17aの例で説明した力 マウス 17bを用 いた場合も全く同様であり、施術者は専ら画面 16を見ながら、画面 16上で指示を与 えることができる。
[0029] 本発明に係る遠隔操作システムの第 2の実施形態を図 2に示す。本実施形態では 、施術者が患者力 遠く離れた場所にいる場合に使用できるように、以下のように構 成されている。患者側には、第 1の実施形態のものと同様の手術具 11、撮影具 12、 駆動部 13、撮像部 14及び患者側制御部 15Aを患者側装置 21として配置する。一 方、施術者側には、第 1の実施形態のものと同様の外部表示部 16及び入力部 17並 びにそれらを制御するための施術者側制御部 15Bを施術者側装置 22として配置す る。そして、患者側装置 21と施術者側装置 22をインターネット 23により接続する。
[0030] 第 2実施形態のシステムは、情報の伝送に通信回線 (LAN,インターネット等)を使 用する点を除いて第 1実施形態のシステムと同じ構成を有するため、第 2実施形態の システムの動作は第 1実施形態のものと同様である。そのため、施術者は患者がすぐ 近くに居る場合と同じ感覚で、遠く離れた場所に居る患者に対して手術をすることが できる。
[0031] ここまでは手術システムを例に説明した力 本発明はもちろん手術システム以外の 遠隔操作システムに適用することができる。例えば、上述のように酸素、水、埃等を排 除した環境下で対象物の加工を行う場合、それらを排除した容器内に対象物を収容 したうえで、本発明のシステムを用いて容器外力ゝら工具を遠隔操作することができる。 本発明によれば、対象物を収容可能な比較的小さい容器を用いることができるため、 建設、維持及び運転に多額のコストを要するクリーンルームを用いる場合よりもコスト を抑えることができる。
[0032] また、体壁や容器などの隔壁がな!ヽ場合にお!ヽても、本発明に係る遠隔操作シス テムを好適に用いることができる。例えば、肉眼では確認することができないほど小さ V、対象物を加工する場合や、肉眼では確認することができな 、微細な加工を行う場 合には、外部表示部において対象物あるいは加工部分を拡大表示することにより、 操作者が操作具の動きを入力部カゝら精密に指示することができ、それにより精密な 加工が可能となる。
実施例
[0033] 本発明の具体的実施例を図 3〜図 5を用いて説明する。本実施例のシステムの基 本的構成は前記第 1実施形態及び第 2実施形態の手術システムと同じである。以下 では、その制御方法について、順を追って説明する。なお、以下では上記手術具を ツール、駆動部をロボット、撮影具を内視鏡、外部表示部をディスプレイと呼ぶ。
[0034] [1]問題設定
ディスプレイ上に表示される画像には、 3種の点座標がある(図 4(a))。
(1)操作者より指示される画面上の目標点座標 D(x ,y )
d d
(2)ツール先端点の画像座標 S(x ,y )
(3)ツール 11に装着されたレーザスポット点の画像座標 P(x ,y )
ここで注意すべきことは、操作者が画面上で目標点を与えても、奥行きの座標 Zが d 決定できな 、ので、対応する対象物 (体内)の 3D座標は決まらな ヽと 、うことである。 従って、この状態ではツール先端を目標点に 3D位置決めすることはできな 、。 そこで、ツール 11の先端にレーザポインタ(レーザ発射部)を取り付け、画像上でそ のレーザスポット点を目標点に位置決めすることで、ツール先端を目標点に 3D位置 決めすることが可能になる。
[0035] [2]ツールの移動速度とレーザスポット点の画像速度の関係
ツール 11はロボットで把持され、制御される力 前記の通り、ツール 11は体表に穿 孔された単孔に挿入されているため(図 3)、その挿入点 Aによる運動学的拘束を受 け、運動学的自由度は次の通り 4となる。
,挿入点 Aを中心とする球面 (回動)運動 2自由度
•ツール軸まわりの回転 1自由度
•ツール軸に沿った並進 1自由度
よって、ツール 11を制御するロボットには 4つの関節があればよい。
[0036] ここで、ロボットの速度制御について考える。いま、挿入点 Aを中心とするツール先 端の 2自由度の回動速度を ( ω , ω )、ツールの軸まわりの回転速度を ω 、ツールの 軸に沿った並進速度を Vとすると、レーザスポット点 P(x ,y )は ( ω ,ν )に無関係であり ρ ρ
、(ω , ω )のみに依存する。すると、レーザスポット点 P(x ,y )の画像速度
Υ P P
[数 1]
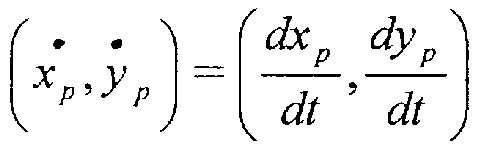
と、ツール先端の回動速度の関係 ( ω , ω )の関係は、
[数 2]

ここに、 Jはイメージヤコビ行列(ヤコビアン)であり、
J =
、 21 22ノ と表される。
[0037] 一般に、ヤコビ行歹 は、カメラ (内視鏡)パラメータ、カメラ (内視鏡) 12とツール 11の 位置関係、ツール 11とターゲット (レーザスポット点)間の距離に依存して変動する力 本実施例の場合、ほぼ固定して制御することが可能であるため、事前のキヤリブレー シヨンにより Jを固定することが可能となる。すなわち、ロボット(ツール)の回動速度 (ω , ω )を変化させたとき、レーザスポット点 P(x ,y )がどのように変化するかを予め校正 Υ P P
しておけばよい。
[0038] [3]レーザスポット点 P(x ,y )を目標点 D(x ,y )に近づける手順
p p d d
P(x ,y )^D(x ,y )に近づけるには、
p p d d
画
 (但し、 k , k〉0)
1 2
という画像速度でレーザスポット点 P(x ,y )を動力せばよい。そのためには、
P P
[数 5]
0)x

そこで、次の (1)〜(4)の手順により近づけることになる。
(1)画像処理により、レーザスポット点 P(x ,y )を検出する。
P P
(2)ロボット(ツール)の回動速度 (ω , ω )を、
[数 6]

により計算する。
(3)計算された回動速度 (ω ,ω )を実現するように、ロボットの各関節の角速度を制 御する。
(4)終了条件
レーザスポット点 P(x ,y )と目標点 D(x ,y )の間の距離
p p d d
[数 7] dpLl = V("¾— ,)2 + 0' /ー /,)' が所定の値 ε 以下になったとき、すなわち、
Ρ
[数 8] く
を満たせば終了する (図 4(b))。さもなければ (1)に戻る。
[0040] [4]ツール先端点 S(x ,y )を目標点 D(x ,y )に近づける手順
s s d d
S(x ,y )を目標点 D(x ,y )に近づけるには、両者間の距離
s s d a
[数 9] dst, =、/( - x 2 + (y, y,Y
に比例した速度、すなわち k -d (但し、 k〉0)という速度でツールを体内に挿入 (軸に
3 sd 3
沿って並進)すればよい。
[0041] そこで、上記同様、次のような手順で近づけることになる。
(1)画像処理により、ツール先端点 S(x ,y)を検出
s s
(2)ツールの並進速度 Vを
z
[数 10]
により計算する。
(3)計算された並進速度 Vを実現するように、ロボットの各関節の角速度を制御する z
(4)終了条件
< £3
が満たされれば終了する (図 4(c》。さもなければ (1)に戻る。
[0042] 実際には、レーザスポット点 P(x ,y )と目標点 D(x ,y )の間の距離 d が所定値 ε (た だし、 ε > ε )以下になったときは、 [3]と [4]の処理 (動き)は同時並行的に行うこと 力 Sできる(図 5(b)→(c)(d》。
[0043] 本発明のシステムでは、ツール先端点 Sが目標点 Dに近づ 、た後、或いは、ツール 先端点 Sが目標点 Dに近づく間、更にはレーザスポット点 Pが目標点 Dに近づく間であ つても、操作者 (施術者)が画面上で指示点 Dを移動させると、ツール先端点 S (及び レーザスポット点 P)もそれに追従して移動する。従って、その間、ツールを手術可能 状態にしておく(すなわち、照射、切除、切断、焼灼等が可能な状態にしておく)こと により、施術者が画面上で指示するのみで照射、切除、切断、焼灼等の施術が可能 となる。
[0044] [5]制御プログラムの構成
上記のようなツール(ロボット)の制御を行うためのプログラムは、次のような要素で 構成することができる。
(1)画像処理パート
画像カゝらレーザスポット点 P(x ,y )及びツール先端点 S(x ,y )を検出する(リアルタイム
)プログラム
(2)ロボット制御パート
ツールの 4自由度の回動 ·並進速度 (ω , ω , ω ,ν )を実現するように、ロボットの各 関節角速度を制御するプログラム
(3)タツチパネノレ ユーザインタフェース パート
目標点を検出するプログラム、校正プロセス、オンライン制御プロセスの切替、各パ ラメータの設定などのユーザインタフェース(すべてタツチパネルで設定)
(4)校正によりヤコビ行歹 IJ [[を作成するプログラム
(5)レーザスポット点 P(x ,y )を目標点 D(x ,y )に近づけるための制御プログラム
(6)ツール先端点 S(x ,y )を目標点 D(x ,y )に近づけるための制御プログラム なお、入力部をマウスとした場合には、(3)は、マウス ユーザインタフェース パート
となる。
本実施例ではツールが単孔に拘束されると!/、う条件の下でツールの運動学的自由 度を 4とした力 ツールが単孔に拘束されない場合には、ツールの運動学的自由度 を 5以上として解析を行い、その結果に基づいてツールを操作することができる。また 、本実施例では上記条件下での運動学的自由度に合わせてロボットの関節の数を 4 としたが、ロボット若しくはツールの関節の数又は両者を合わせた数を 5以上とするこ とも、もちろん可能である。
Claims
[1] 対象物に対して操作を行う遠隔操作システムにお 、て、
a)前記対象物を撮影する撮影具と、
b)前記対象物を照射するスポット光照射部を先端に有する操作具と、 c)前記操作具の位置を変化させる駆動部と、
d)前記撮影具により撮影された映像を表示する外部表示部と、
e)操作者が、外部表示部の表示に対応した位置を指示するための入力部と、
D入力部を介して指示された位置と、前記スポット光照射部により前記対象物に照 射されたスポット光の位置の間の距離を計算する距離計算部と、
g)前記距離に基づき、操作具先端が前記指示位置に近づくように駆動部を制御す る制御部と、
を備えることを特徴とする遠隔操作システム。
[2] 前記制御部が、前記距離が小さくなるように手術具を移動させ、前記距離が所定値 以下になった後に、手術具の先端を指示位置に近づけることを特徴とする請求項 1 に記載の遠隔操作システム。
[3] 前記対象物が患者の患部であり、前記操作具が手術具であることを特徴とする請 求項 1又は 2に記載の遠隔操作システム。
[4] 隔壁の向こう側の空間内にある対象物に対して操作を行う遠隔操作システムにお いて、
a)前記対象物を撮影する撮影具と、
b)前記隔壁に設けられた単孔を通して前記空間に挿入される、先端にスポット光 照射部を有する棒状の操作具と、
c)前記操作具の位置を変化させる駆動部と、
d)撮影具により撮影された映像を表示する外部表示部と、
e)操作者が、外部表示部の表示に対応した位置を指示するための入力部と、
D入力部を介して指示された位置と、前記スポット光照射部により前記対象物に照 射されたスポット光の位置の間の距離を計算する距離計算部と、
g)前記距離に基づき、操作具先端が前記指示位置に近づくように駆動部を制御す
る制御部と、
を備えることを特徴とする遠隔操作システム。
[5] 前記制御部が、
まず前記距離が小さくなるように操作具を前記単孔を中心として回動させ、 前記距離が所定値以下になった後に、操作具をその軸方向に移動させる、 ように駆動部を制御することを特徴とする請求項 4又は 10に記載の遠隔操作システ ム。
[6] 更に、前記制御部が該操作具を軸まわりにも回転させることを特徴とする請求項 4
〜5の 、ずれかに記載の遠隔操作システム。
[7] 前記撮影具によつて撮影された画像上の前記スポット位置の情報を前記駆動部の 回動に係わる駆動パラメータに変換するヤコビ行列に基づいて前記駆動パラメータ を変化させることにより前記操作具の動きを制御することを特徴とする請求項 4〜6の
V、ずれかに記載の遠隔操作システム。
[8] 前記制御部が、前記撮影具によつて撮影された画像上の操作具先端部の位置情 報に基づいて前記操作具の進入 ·後退に力かわる前記駆動部の駆動パラメータを変 化させることにより前記操作具の動きを制御することを特徴とする請求項 4〜7のいず れかに記載の遠隔操作システム。
[9] 前記対象物が患者の患部であり、前記隔壁が患者の体壁であって、
前記操作具が手術具である、
ことを特徴とする請求項 4〜8のいずれかに記載の遠隔操作システム。
[10] 前記入力部が、前記外部表示部に装着されたタツチパネルであることを特徴とする 請求項 1〜9のいずれかに記載の遠隔操作システム。
[11] 前記制御部が、前記指示位置が移動したときに前記距離が所定値以下である状態 が維持されるように前記駆動部を制御する機能を備えることを特徴とする請求項 1〜
10の 、ずれかに記載の遠隔操作システム。
[12] 前記制御部が、前記操作具の動きを速度制御により制御することを特徴とする請求 項 1〜: L 1のいずれかに記載の遠隔操作システム。
[13] 請求項 1〜12のいずれかに記載の遠隔操作システムのうち少なくとも前記外部表
示部及び前記入力部を有することを特徴とする遠隔操作システム用操作者側装置。 請求項 1〜13のいずれかに記載の遠隔操作システムのうち少なくとも前記撮影具、 前記操作具及び前記駆動部を有することを特徴とする遠隔操作システム用対象物側 装置。
Priority Applications (3)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| JP2008521275A JP5384108B2 (ja) | 2006-06-15 | 2007-06-15 | 遠隔操作システム |
| EP07767124.6A EP2057955A4 (en) | 2006-06-15 | 2007-06-15 | REMOTE CONTROL SYSTEM |
| US12/308,380 US8734431B2 (en) | 2006-06-15 | 2007-06-15 | Remote control system |
Applications Claiming Priority (2)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| JP2006-166381 | 2006-06-15 | ||
| JP2006166381 | 2006-06-15 |
Publications (1)
| Publication Number | Publication Date |
|---|---|
| WO2007145327A1 true WO2007145327A1 (ja) | 2007-12-21 |
Family
ID=38831840
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| PCT/JP2007/062147 Ceased WO2007145327A1 (ja) | 2006-06-15 | 2007-06-15 | 遠隔操作システム |
Country Status (4)
| Country | Link |
|---|---|
| US (1) | US8734431B2 (ja) |
| EP (1) | EP2057955A4 (ja) |
| JP (1) | JP5384108B2 (ja) |
| WO (1) | WO2007145327A1 (ja) |
Cited By (7)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN103442662A (zh) * | 2011-03-31 | 2013-12-11 | 奥林巴斯株式会社 | 用于手术系统的控制装置和控制方法 |
| JP2014513578A (ja) * | 2011-02-21 | 2014-06-05 | リムサイエンス カンパニー リミテッド | 使用者指定によって決定される変位情報に基づいて手術を行う手術用ロボットシステムとその制御方法 |
| JP2015080845A (ja) * | 2013-10-24 | 2015-04-27 | オリンパス株式会社 | 医療用マニピュレータおよび医療用マニピュレータの初期化方法 |
| JP2016528010A (ja) * | 2013-08-23 | 2016-09-15 | エシコン・エンド−サージェリィ・エルエルシーEthicon Endo−Surgery, LLC | 外科用器具のための対話型ディスプレイ |
| JP2017000771A (ja) * | 2015-06-12 | 2017-01-05 | アヴァテラメディカル ゲーエムベーハー | 位置調整デバイス並びにロボット支援手術のための装置及び方法 |
| JP2017532145A (ja) * | 2014-10-23 | 2017-11-02 | コヴィディエン リミテッド パートナーシップ | 外科手術用ポートアセンブリを使用して外科手術用器具を制御する方法および装置 |
| JP2021142106A (ja) * | 2020-03-12 | 2021-09-24 | 株式会社セオコーポレーション | 無影灯 |
Families Citing this family (63)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| US9060770B2 (en) | 2003-05-20 | 2015-06-23 | Ethicon Endo-Surgery, Inc. | Robotically-driven surgical instrument with E-beam driver |
| US9072535B2 (en) | 2011-05-27 | 2015-07-07 | Ethicon Endo-Surgery, Inc. | Surgical stapling instruments with rotatable staple deployment arrangements |
| US8186555B2 (en) | 2006-01-31 | 2012-05-29 | Ethicon Endo-Surgery, Inc. | Motor-driven surgical cutting and fastening instrument with mechanical closure system |
| US20120292367A1 (en) | 2006-01-31 | 2012-11-22 | Ethicon Endo-Surgery, Inc. | Robotically-controlled end effector |
| US8708213B2 (en) | 2006-01-31 | 2014-04-29 | Ethicon Endo-Surgery, Inc. | Surgical instrument having a feedback system |
| US7845537B2 (en) | 2006-01-31 | 2010-12-07 | Ethicon Endo-Surgery, Inc. | Surgical instrument having recording capabilities |
| US11793518B2 (en) | 2006-01-31 | 2023-10-24 | Cilag Gmbh International | Powered surgical instruments with firing system lockout arrangements |
| US8992422B2 (en) | 2006-03-23 | 2015-03-31 | Ethicon Endo-Surgery, Inc. | Robotically-controlled endoscopic accessory channel |
| US11980366B2 (en) | 2006-10-03 | 2024-05-14 | Cilag Gmbh International | Surgical instrument |
| US8840603B2 (en) | 2007-01-10 | 2014-09-23 | Ethicon Endo-Surgery, Inc. | Surgical instrument with wireless communication between control unit and sensor transponders |
| US8684253B2 (en) | 2007-01-10 | 2014-04-01 | Ethicon Endo-Surgery, Inc. | Surgical instrument with wireless communication between a control unit of a robotic system and remote sensor |
| US11564682B2 (en) | 2007-06-04 | 2023-01-31 | Cilag Gmbh International | Surgical stapler device |
| US8573465B2 (en) | 2008-02-14 | 2013-11-05 | Ethicon Endo-Surgery, Inc. | Robotically-controlled surgical end effector system with rotary actuated closure systems |
| US8636736B2 (en) | 2008-02-14 | 2014-01-28 | Ethicon Endo-Surgery, Inc. | Motorized surgical cutting and fastening instrument |
| US11986183B2 (en) | 2008-02-14 | 2024-05-21 | Cilag Gmbh International | Surgical cutting and fastening instrument comprising a plurality of sensors to measure an electrical parameter |
| US20130153641A1 (en) | 2008-02-15 | 2013-06-20 | Ethicon Endo-Surgery, Inc. | Releasable layer of material and surgical end effector having the same |
| US8210411B2 (en) | 2008-09-23 | 2012-07-03 | Ethicon Endo-Surgery, Inc. | Motor-driven surgical cutting instrument |
| US10945731B2 (en) | 2010-09-30 | 2021-03-16 | Ethicon Llc | Tissue thickness compensator comprising controlled release and expansion |
| US11925354B2 (en) | 2010-09-30 | 2024-03-12 | Cilag Gmbh International | Staple cartridge comprising staples positioned within a compressible portion thereof |
| US9629814B2 (en) | 2010-09-30 | 2017-04-25 | Ethicon Endo-Surgery, Llc | Tissue thickness compensator configured to redistribute compressive forces |
| US12213666B2 (en) | 2010-09-30 | 2025-02-04 | Cilag Gmbh International | Tissue thickness compensator comprising layers |
| US11812965B2 (en) | 2010-09-30 | 2023-11-14 | Cilag Gmbh International | Layer of material for a surgical end effector |
| US10405854B2 (en) | 2010-09-30 | 2019-09-10 | Ethicon Llc | Surgical stapling cartridge with layer retention features |
| US11309081B2 (en) | 2010-10-13 | 2022-04-19 | Gholam A. Peyman | Telemedicine system with dynamic imaging |
| US12502074B2 (en) | 2010-10-13 | 2025-12-23 | Gholam A. Peyman | Telemedicine system with dynamic imaging |
| US10456209B2 (en) * | 2010-10-13 | 2019-10-29 | Gholam A. Peyman | Remote laser treatment system with dynamic imaging |
| JP6105041B2 (ja) | 2012-03-28 | 2017-03-29 | エシコン・エンド−サージェリィ・インコーポレイテッドEthicon Endo−Surgery,Inc. | 低圧環境を画定するカプセルを含む組織厚コンペンセーター |
| US20140001231A1 (en) | 2012-06-28 | 2014-01-02 | Ethicon Endo-Surgery, Inc. | Firing system lockout arrangements for surgical instruments |
| US9700310B2 (en) | 2013-08-23 | 2017-07-11 | Ethicon Llc | Firing member retraction devices for powered surgical instruments |
| MX368026B (es) | 2013-03-01 | 2019-09-12 | Ethicon Endo Surgery Inc | Instrumento quirúrgico articulable con vías conductoras para la comunicación de la señal. |
| BR112015026109B1 (pt) | 2013-04-16 | 2022-02-22 | Ethicon Endo-Surgery, Inc | Instrumento cirúrgico |
| JP6010225B2 (ja) * | 2013-06-13 | 2016-10-19 | テルモ株式会社 | 医療用マニピュレータ |
| US9690362B2 (en) | 2014-03-26 | 2017-06-27 | Ethicon Llc | Surgical instrument control circuit having a safety processor |
| BR112016023825B1 (pt) | 2014-04-16 | 2022-08-02 | Ethicon Endo-Surgery, Llc | Cartucho de grampos para uso com um grampeador cirúrgico e cartucho de grampos para uso com um instrumento cirúrgico |
| JP6636452B2 (ja) | 2014-04-16 | 2020-01-29 | エシコン エルエルシーEthicon LLC | 異なる構成を有する延在部を含む締結具カートリッジ |
| CN106413614B (zh) | 2014-05-30 | 2021-04-16 | 百派德股份有限公司 | 双极电刀致动器 |
| KR102284639B1 (ko) * | 2014-06-26 | 2021-08-02 | 한국과학기술원 | 펜 형태의 인터페이스를 이용한 수술 도구 제어 시스템 |
| US10105142B2 (en) | 2014-09-18 | 2018-10-23 | Ethicon Llc | Surgical stapler with plurality of cutting elements |
| US9924944B2 (en) | 2014-10-16 | 2018-03-27 | Ethicon Llc | Staple cartridge comprising an adjunct material |
| US11154301B2 (en) | 2015-02-27 | 2021-10-26 | Cilag Gmbh International | Modular stapling assembly |
| US9808246B2 (en) | 2015-03-06 | 2017-11-07 | Ethicon Endo-Surgery, Llc | Method of operating a powered surgical instrument |
| US10299878B2 (en) | 2015-09-25 | 2019-05-28 | Ethicon Llc | Implantable adjunct systems for determining adjunct skew |
| US11890015B2 (en) | 2015-09-30 | 2024-02-06 | Cilag Gmbh International | Compressible adjunct with crossing spacer fibers |
| US11690623B2 (en) | 2015-09-30 | 2023-07-04 | Cilag Gmbh International | Method for applying an implantable layer to a fastener cartridge |
| CN105242687A (zh) * | 2015-10-29 | 2016-01-13 | 桂林创研科技有限公司 | 一种无人机遥控方法 |
| USD778442S1 (en) | 2015-11-19 | 2017-02-07 | Bipad, Llc | Bipolar electrosurgery actuator system |
| US10265068B2 (en) | 2015-12-30 | 2019-04-23 | Ethicon Llc | Surgical instruments with separable motors and motor control circuits |
| US10357247B2 (en) | 2016-04-15 | 2019-07-23 | Ethicon Llc | Surgical instrument with multiple program responses during a firing motion |
| CN106256310B (zh) * | 2016-08-18 | 2018-04-13 | 中国科学院深圳先进技术研究院 | 自动调节鼻内镜位姿的方法和系统 |
| US10646268B2 (en) | 2016-08-26 | 2020-05-12 | Bipad, Inc. | Ergonomic actuator for electrosurgical tool |
| US10639035B2 (en) | 2016-12-21 | 2020-05-05 | Ethicon Llc | Surgical stapling instruments and replaceable tool assemblies thereof |
| EP3420947B1 (en) | 2017-06-28 | 2022-05-25 | Cilag GmbH International | Surgical instrument comprising selectively actuatable rotatable couplers |
| US10765427B2 (en) | 2017-06-28 | 2020-09-08 | Ethicon Llc | Method for articulating a surgical instrument |
| US11134944B2 (en) | 2017-10-30 | 2021-10-05 | Cilag Gmbh International | Surgical stapler knife motion controls |
| US10842490B2 (en) | 2017-10-31 | 2020-11-24 | Ethicon Llc | Cartridge body design with force reduction based on firing completion |
| US10835330B2 (en) | 2017-12-19 | 2020-11-17 | Ethicon Llc | Method for determining the position of a rotatable jaw of a surgical instrument attachment assembly |
| CN108186121B (zh) * | 2018-01-08 | 2020-09-11 | 苏风波 | 一种外科随动机器手臂 |
| US20200054321A1 (en) | 2018-08-20 | 2020-02-20 | Ethicon Llc | Surgical instruments with progressive jaw closure arrangements |
| US12376923B2 (en) * | 2018-10-15 | 2025-08-05 | Intuitive Surgical Operations, Inc. | Systems and methods for sterilization and storage of a sterilized teleoperated component |
| US11812926B2 (en) * | 2019-12-03 | 2023-11-14 | Boston Scientific Scimed, Inc. | Medical device tracking systems and methods of using the same |
| US11826042B2 (en) | 2021-03-22 | 2023-11-28 | Cilag Gmbh International | Surgical instrument comprising a firing drive including a selectable leverage mechanism |
| US11723658B2 (en) | 2021-03-22 | 2023-08-15 | Cilag Gmbh International | Staple cartridge comprising a firing lockout |
| CN115810216A (zh) * | 2021-09-14 | 2023-03-17 | 索尼互动娱乐股份有限公司 | 信息处理装置 |
Citations (5)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JPH02198784A (ja) * | 1989-01-23 | 1990-08-07 | Nissan Motor Co Ltd | アーク溶接ロボットの教示位置確認装置 |
| JPH0630896A (ja) | 1992-05-27 | 1994-02-08 | Internatl Business Mach Corp <Ibm> | 外科的治療方法及び装置 |
| JPH08215205A (ja) | 1995-02-13 | 1996-08-27 | Olympus Optical Co Ltd | 医療用マニピュレータ |
| JP2002253574A (ja) * | 2001-03-01 | 2002-09-10 | Hitachi Ltd | 手術支援装置 |
| JP2003052716A (ja) | 2001-08-10 | 2003-02-25 | Toshiba Corp | 医療用マニピュレータシステム |
Family Cites Families (4)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| US6021342A (en) * | 1997-06-30 | 2000-02-01 | Neorad A/S | Apparatus for assisting percutaneous computed tomography-guided surgical activity |
| DE19842239A1 (de) * | 1998-09-15 | 2000-03-16 | Siemens Ag | Medizintechnische Einrichtung |
| US7542791B2 (en) * | 2003-01-30 | 2009-06-02 | Medtronic Navigation, Inc. | Method and apparatus for preplanning a surgical procedure |
| JP4512405B2 (ja) * | 2004-04-23 | 2010-07-28 | 本田技研工業株式会社 | 3次元形状測定方法 |
-
2007
- 2007-06-15 WO PCT/JP2007/062147 patent/WO2007145327A1/ja not_active Ceased
- 2007-06-15 US US12/308,380 patent/US8734431B2/en not_active Expired - Fee Related
- 2007-06-15 EP EP07767124.6A patent/EP2057955A4/en not_active Withdrawn
- 2007-06-15 JP JP2008521275A patent/JP5384108B2/ja not_active Expired - Fee Related
Patent Citations (5)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JPH02198784A (ja) * | 1989-01-23 | 1990-08-07 | Nissan Motor Co Ltd | アーク溶接ロボットの教示位置確認装置 |
| JPH0630896A (ja) | 1992-05-27 | 1994-02-08 | Internatl Business Mach Corp <Ibm> | 外科的治療方法及び装置 |
| JPH08215205A (ja) | 1995-02-13 | 1996-08-27 | Olympus Optical Co Ltd | 医療用マニピュレータ |
| JP2002253574A (ja) * | 2001-03-01 | 2002-09-10 | Hitachi Ltd | 手術支援装置 |
| JP2003052716A (ja) | 2001-08-10 | 2003-02-25 | Toshiba Corp | 医療用マニピュレータシステム |
Non-Patent Citations (3)
| Title |
|---|
| A. KRUPA ET AL.: "Autonomous 3-D Positioning of Surgical Instruments in Robotized Laparoscopic Surgery Using Visual Servoing", IEEE TRANS. ON ROBOTICS AND AUTOMATION, vol. 19, no. 5, 2003, pages 842 - 853, XP011102058, DOI: doi:10.1109/TRA.2003.817086 |
| KRUPA A. ET AL.: "Autonomous 3D Positioning of Surgical Instruments in Robotized Laparoscopic Surgery Using Visual Servoing", IEEE TRANS. ON ROBOTICS AND AUTOMATION, vol. 19, no. 5, 2003, XP011102058 * |
| See also references of EP2057955A4 * |
Cited By (10)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JP2014513578A (ja) * | 2011-02-21 | 2014-06-05 | リムサイエンス カンパニー リミテッド | 使用者指定によって決定される変位情報に基づいて手術を行う手術用ロボットシステムとその制御方法 |
| CN103442662A (zh) * | 2011-03-31 | 2013-12-11 | 奥林巴斯株式会社 | 用于手术系统的控制装置和控制方法 |
| JP2016528010A (ja) * | 2013-08-23 | 2016-09-15 | エシコン・エンド−サージェリィ・エルエルシーEthicon Endo−Surgery, LLC | 外科用器具のための対話型ディスプレイ |
| JP2015080845A (ja) * | 2013-10-24 | 2015-04-27 | オリンパス株式会社 | 医療用マニピュレータおよび医療用マニピュレータの初期化方法 |
| WO2015060428A1 (ja) * | 2013-10-24 | 2015-04-30 | オリンパス株式会社 | 医療用マニピュレータおよび医療用マニピュレータの初期化方法 |
| CN105682600A (zh) * | 2013-10-24 | 2016-06-15 | 奥林巴斯株式会社 | 医疗用机械手和医疗用机械手的初始化方法 |
| US10398515B2 (en) | 2013-10-24 | 2019-09-03 | Olympus Corporation | Medical manipulator and initialization method for medical manipulator |
| JP2017532145A (ja) * | 2014-10-23 | 2017-11-02 | コヴィディエン リミテッド パートナーシップ | 外科手術用ポートアセンブリを使用して外科手術用器具を制御する方法および装置 |
| JP2017000771A (ja) * | 2015-06-12 | 2017-01-05 | アヴァテラメディカル ゲーエムベーハー | 位置調整デバイス並びにロボット支援手術のための装置及び方法 |
| JP2021142106A (ja) * | 2020-03-12 | 2021-09-24 | 株式会社セオコーポレーション | 無影灯 |
Also Published As
| Publication number | Publication date |
|---|---|
| US20090187288A1 (en) | 2009-07-23 |
| JP5384108B2 (ja) | 2014-01-08 |
| EP2057955A1 (en) | 2009-05-13 |
| US8734431B2 (en) | 2014-05-27 |
| JPWO2007145327A1 (ja) | 2009-11-12 |
| EP2057955A4 (en) | 2016-04-20 |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| JP5384108B2 (ja) | 遠隔操作システム | |
| US20220249193A1 (en) | Systems and methods for presenting augmented reality in a display of a teleoperational system | |
| JP7295153B2 (ja) | 遠隔操作医療システムにおける器具のオフスクリーン表示のためのシステム及び方法 | |
| JP7229319B2 (ja) | 手術支援装置、その制御方法、プログラム並びに手術支援システム | |
| JP6714085B2 (ja) | ロボット手術のために仮想現実デバイスを使用するシステム、コントローラ、及び方法 | |
| JP5568574B2 (ja) | 内視鏡装置をナビゲーションする方法、および画像表示のための装置 | |
| JP5030639B2 (ja) | 内視鏡装置の処置具位置制御装置 | |
| EP3429496B1 (en) | Control unit, system and method for controlling hybrid robot having rigid proximal portion and flexible distal portion | |
| KR20140110685A (ko) | 싱글 포트 수술 로봇의 제어 방법 | |
| JPWO2018159338A1 (ja) | 医療用支持アームシステムおよび制御装置 | |
| WO2024145341A1 (en) | Systems and methods for generating 3d navigation interfaces for medical procedures | |
| JP2019188038A (ja) | 外科手術システム及び外科手術システムの制御方法 | |
| CN108472090A (zh) | 用于控制外科手术机器人的系统、控制单元和方法 | |
| KR20230029999A (ko) | 원격조작 의료 시스템에서 기구의 스크린상 식별정보를 렌더링하기 위한 시스템 및 방법 | |
| CN114760903A (zh) | 用于在外科手术期间控制图像捕获设备的方法、装置、以及系统 | |
| US20230120627A1 (en) | Service life management for an instrument of a robotic surgery system | |
| JP2026502809A (ja) | ガイド付きツール交換の復元性のためのシステム及び方法 | |
| US20250134610A1 (en) | Systems and methods for remote mentoring in a robot assisted medical system | |
| CN119950040A (zh) | 手术机器人系统的控制方法、相应的计算机可读存储介质、程序产品、控制装置以及手术机器人系统 | |
| CN115886695A (zh) | 手持机器人辅助式内窥镜 | |
| RU2721461C1 (ru) | Способ управления камерой в роботохирургическом комплексе | |
| US20260060514A1 (en) | Camera calibration for surgical systems | |
| EP4483831A1 (en) | Robotic assembly for a surgical system | |
| CN119924762A (zh) | 电子硬镜及包括其的电子硬镜控制组件、手术机器人系统以及控制电子硬镜运动的方法 | |
| CN121889826A (zh) | 解剖对象的模型的计算机辅助配准和跟踪 |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| 121 | Ep: the epo has been informed by wipo that ep was designated in this application |
Ref document number: 07767124 Country of ref document: EP Kind code of ref document: A1 |
|
| WWE | Wipo information: entry into national phase |
Ref document number: 2008521275 Country of ref document: JP |
|
| DPE1 | Request for preliminary examination filed after expiration of 19th month from priority date (pct application filed from 20040101) | ||
| NENP | Non-entry into the national phase |
Ref country code: DE |
|
| WWE | Wipo information: entry into national phase |
Ref document number: 2007767124 Country of ref document: EP |
|
| WWE | Wipo information: entry into national phase |
Ref document number: 12308380 Country of ref document: US |
|
| DPE1 | Request for preliminary examination filed after expiration of 19th month from priority date (pct application filed from 20040101) |