WO2011049079A1 - 作業機械 - Google Patents
作業機械 Download PDFInfo
- Publication number
- WO2011049079A1 WO2011049079A1 PCT/JP2010/068356 JP2010068356W WO2011049079A1 WO 2011049079 A1 WO2011049079 A1 WO 2011049079A1 JP 2010068356 W JP2010068356 W JP 2010068356W WO 2011049079 A1 WO2011049079 A1 WO 2011049079A1
- Authority
- WO
- WIPO (PCT)
- Prior art keywords
- work
- work machine
- zmp
- traveling body
- sensor
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Ceased
Links
Images


Classifications
-
- E—FIXED CONSTRUCTIONS
- E02—HYDRAULIC ENGINEERING; FOUNDATIONS; SOIL SHIFTING
- E02F—DREDGING; SOIL-SHIFTING
- E02F9/00—Component parts of dredgers or soil-shifting machines, not restricted to one of the kinds covered by groups E02F3/00 - E02F7/00
- E02F9/24—Safety devices, e.g. for preventing overload
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B66—HOISTING; LIFTING; HAULING
- B66C—CRANES; LOAD-ENGAGING ELEMENTS OR DEVICES FOR CRANES, CAPSTANS, WINCHES, OR TACKLES
- B66C23/00—Cranes comprising essentially a beam, boom, or triangular structure acting as a cantilever and mounted for translatory of swinging movements in vertical or horizontal planes or a combination of such movements, e.g. jib-cranes, derricks, tower cranes
- B66C23/88—Safety gear
- B66C23/90—Devices for indicating or limiting lifting moment
- B66C23/905—Devices for indicating or limiting lifting moment electrical
-
- E—FIXED CONSTRUCTIONS
- E02—HYDRAULIC ENGINEERING; FOUNDATIONS; SOIL SHIFTING
- E02F—DREDGING; SOIL-SHIFTING
- E02F9/00—Component parts of dredgers or soil-shifting machines, not restricted to one of the kinds covered by groups E02F3/00 - E02F7/00
- E02F9/26—Indicating devices
- E02F9/264—Sensors and their calibration for indicating the position of the work tool
Definitions
- the present invention relates to a work machine, and particularly to a work machine used for construction work, dismantling work, civil engineering work, and the like.
- an upper swinging body is pivotably attached to the lower traveling body, and an articulated work front is attached to the upper swinging body so that it can swing up and down. Things are known.
- An example of such a work machine is a dismantling work machine based on a hydraulic excavator.
- Such a work machine connects a work front composed of a boom and an arm to an upper swing body via a joint so that the work front can swing up and down, and further attaches a grapple, bucket, breaker, crusher, etc. to the tip of the arm via a joint. It is installed to perform work such as structure demolition work and waste demolition work.
- Patent Document 1 is presented as a conventional technique related to this problem.
- angle sensors are attached to the boom and arm of the work machine, a control device is provided in the work machine, and a detection signal from the angle sensor is input to the control device.
- the control device calculates the support force of the stable fulcrum on the ground plane position of the entire work machine and the ground contact surface of the lower traveling body based on the detection signal, and displays the support force value at the stable fulcrum based on the calculation result on the display device. ing.
- an alarm is issued when the supporting force at the rear stable fulcrum of the work machine falls below a limit value for ensuring safe work.
- Patent Document 2 is presented.
- a boom angle, an arm angle, a bucket angle, and an angle sensor that detects a turning angle of the upper swing body and an inclination angle sensor that detects a tilt in the front-rear direction of the vehicle body are provided.
- the static overturning moment of the work machine is calculated on the basis of the dimensions of each angle sensor and a predetermined part of the vehicle body.
- the dynamic overturning moment generated by the centrifugal force of the upper turning body is calculated using the turning angular velocity of the upper turning body, and the dynamic overturning moment generated when the upper turning body suddenly stops is the maximum angular acceleration of the turning. Is calculated using. Then, one or the larger of these dynamic overturning moments is added to the static overturning moment, the magnitude of which is used as a fall determination condition, and the turning angular velocity is controlled when the determination condition is satisfied.
- Patent Document 3 is presented.
- the technique disclosed in Patent Document 3 includes sensors that detect the posture, movement, and work load of the main body, and based on the detection values of these sensors, referring to a database, the present and future dynamics relating to the posture of the construction machine main body.
- a model representing the behavior is constructed, and it is determined whether or not the construction machine body falls. When a fall is predicted, the work operation being executed is stopped, and an operation for avoiding the fall is started to prevent the fall. When a fall is predicted, the operator also I will let you know.
- an inertial force is generated by the movement of the work front or the work machine itself during the work, and this inertial force is greatly related to the stability of the work machine.
- the work machine is used for various work, and for example, there is a case where the ground contact state with the ground surface changes depending on the operation such as a jack-up operation in which the front end of the work front is pressed against the ground to lift the main body. Even in such a case, in order to accurately determine the stability, it is necessary to always detect the ground contact state and determine the stability according to the change.
- the present invention has been made in view of these problems, and calculates the dynamic stability considering the inertial force or external force acting on the work machine every moment and the grounding state of the work machine, and displays and warns without delay. It is intended to provide a work machine that can do this.
- the present invention employs the following means in order to solve the above problems.
- a traveling machine a work machine main body mounted on the traveling body, a work front attached to the work machine main body so as to be swingable in the vertical direction, and a work machine equipped with a work tool attached to the work front via a pin
- a plurality of ZMP computing means for calculating the coordinates of the ZMP using the position vector, acceleration vector, and external force vector of each mass point constituting the main body and the traveling body including the work front, and the ground of the work machine.
- the ZMP calculating means and the stability calculating means calculate and display the support polygon including the ZMP and the warning area.
- the dynamic stability and the ground contact state considering the inertial force or external force acting on the work machine can be calculated every moment and displayed without delay.
- FIG. 1 is a schematic side view showing a work machine according to a first embodiment. It is a block diagram which shows the control system structure of a working machine. It is a schematic side view which shows the calculation model of a working machine. It is a figure which shows an example of a support polygon. It is a schematic top view which shows the calculation model of a working machine. It is a figure which shows an example of the setting method of a fall warning area. It is a figure which shows an example of the setting method of a fall warning area. It is a figure which shows an example of the support polygon in a braid
- FIG. 1 is a schematic side view showing the work machine according to the first embodiment.
- an upper swing body 3 is turnably attached to a lower traveling body 2, and the upper swing body 3 is driven to swing by a swing motor 7.
- a cab 4 and an engine 5 are attached to the upper swing body 3.
- a counterweight 8 is attached to the rear of the upper swing body 3.
- the work machine 1 is configured by including a control device 60 that controls the entire work machine 1.
- the upper swing body 3 is provided with a boom 10 that can swing up and down with a fulcrum 40 as a joint, and an arm 12 that is swingable with a fulcrum 41 as a joint at the tip of the boom 10. Further, a bucket 23 as a work tool is provided at the tip of the arm 12 so as to be rotatable with the fulcrum 42 as a joint.
- the boom 10 and the arm 12 constitute a work front 6.
- the boom cylinder 11 is an actuator that drives the boom 10 to rotate around the fulcrum 40 and is connected to the upper swing body 3 and the boom 10.
- the arm cylinder 13 is an actuator that drives the arm 12 to rotate around the fulcrum 41, and is connected to the boom 10 and the arm 12.
- the work tool cylinder 15 is an actuator that drives the bucket 23 to rotate around the fulcrum 42, and is connected to the bucket 23 via the link 16 and the arm 12 via the link 17.
- the bucket 23 can be replaced with other work tools such as grapples, cutters, and breakers.
- the upper swing body 3 is provided with an operator's cab 4 for operating the work machine 1, and an operation device 50 for inputting a movement instruction for each drive actuator from the operator, which will be described later, in the cab 4.
- a display device (display means) 61 for displaying a supporting polygon, a ZMP coordinate, etc., an alarm device (alarm means) 63 for generating a fall warning sound of the work machine 1, and a user setting input device 55 for the operator to make various settings Etc. are provided.
- a blade 18 is provided on the front surface of the lower traveling body 2 so as to be swingable up and down.
- the blade 18 is driven by a blade cylinder 19.
- the upper swing body 3 is provided with an attitude sensor 3b for detecting the inclination of the machine reference coordinate system with respect to the world coordinate system with the Z axis as the direction opposite to gravity, which will be described later.
- the posture sensor 3b is, for example, an inclination angle sensor, and detects the inclination of the machine reference coordinate system with respect to the world coordinate system by detecting the inclination angle of the upper swing body 3.
- a turning angle sensor 3 s for detecting the turning angle of the lower traveling body 2 and the upper turning body 3 is provided on the turning center line 3 c of the upper turning body 3.
- a boom angle sensor (angle sensor) 40 a for measuring the rotation angle of the boom 10 is provided at the fulcrum 40 of the upper swing body 3 and the boom 10.
- the fulcrum 41 of the boom 10 and the arm 12 is provided with an arm angle sensor (angle sensor) 41 a for measuring the rotation angle of the arm 12.
- a bucket angle sensor 42a for measuring the rotation angle of the bucket 23 is provided.
- ⁇ Acceleration sensor> Near the center of gravity of the lower traveling body 2, the upper swing body 3, the boom 10, and the arm 12, a lower traveling body acceleration sensor 2a, an upper swing body acceleration sensor 3a, a boom acceleration sensor 10a, and an arm acceleration sensor 12a are provided. Yes.
- Pin force sensors 43a and 44a are provided on the pin 43 connecting the arm 12 and the bucket 23 and the pin 44 connecting the link 16 and the bucket 23, respectively.
- the pin force sensors 43a and 44a detect the magnitude and direction of the force (external force) applied to the pins 43 and 44 by, for example, inserting a strain gauge inside a cylindrical shape and measuring the strain generated in the strain gauge. .
- the turning motor 7 for turning the upper turning body 3 includes turning motor pressure sensors 7 i and 7 o for detecting the suction side pressure and the discharge side pressure of the hydraulic pressure that drives the turning motor 7. Further, the blade cylinder 19 includes blade cylinder pressure sensors 19i and 19o for detecting the suction side pressure and the discharge side pressure of the hydraulic pressure that drives the blade cylinder 19.
- FIG. 2 is a schematic configuration diagram of a control device provided in the work machine 1.
- the control device 60 includes an input unit 60h to which signals from respective sensors attached to the respective units of the work machine 1 are input, a calculation unit 60g that receives a signal input to the input unit 60h, and performs a predetermined calculation.
- an output unit 60i is provided that outputs the stability information and the fall warning information of the work machine 1 (see FIG. 1).
- the display unit 61 displays the stability information and the overturn warning information of the work machine 1, and the alarm device 63 issues a warning about the overturn.
- the calculation unit 60g is composed of a CPU (Central Processing Unit), a ROM (Read Only Memory), a RAM (Random Access Memory), a flash memory, a storage unit not shown, a microcomputer including these, a peripheral circuit (not shown), and the like. For example, it operates according to a program stored in the ROM.
- a CPU Central Processing Unit
- ROM Read Only Memory
- RAM Random Access Memory
- flash memory a storage unit not shown
- a microcomputer including these a peripheral circuit (not shown), and the like. For example, it operates according to a program stored in the ROM.
- FIG. 3 is a schematic side view showing a ZMP computing work machine model having a control device.
- the world coordinate system (O-XYZ) with the gravity direction as the reference and the reverse direction of gravity as the Z axis and the machine reference coordinate system (O-XYZ) with the lower traveling body 2 as the reference are set as shown in FIG. To do.
- the machine reference coordinate system belongs to the lower traveling body 2, and as shown in FIG. 3, the machine reference coordinate system origin is a point O in contact with the ground surface 30 on the turning center line 3c of the upper turning body 3.
- An X axis is set in the front-rear direction of the traveling body 2
- a Y axis is set in the left-right direction
- a Z axis is set in the vertical direction.
- each constituent member as shown in FIG. 3 uses a concentrated mass model in which mass is concentrated at the center of gravity.
- the mass points 2P, 3P, 10P, 12P of the lower traveling body 2, the upper swing body 3, the boom 10, and the arm 12 are set to the gravity center positions of the respective constituent members, and the masses of the respective mass points are m2, m3, m10, m12.
- the position vectors of the respective mass points are r2, r3, r10, r12, and the acceleration vectors are r ′′ 2, r ′′ 3, r ′′ 10, r ′′ 12.
- the mass point setting method is not limited to this, and for example, a portion where the mass is concentrated (such as the engine 5 and the counterweight 8 shown in FIG. 1) may be added.
- the external force is applied to the tip of the bucket 23 by working with the bucket 23. Since the bucket 23 is connected to the work front 6 via pins 43 and 44, all the gravity and inertial force of the bucket 23 and the external forces applied to the bucket 23 in the X-axis direction and the Z-axis direction are Calculation is performed as external force vectors F43 and F44 applied to the pin 44, and ZMP coordinates are calculated.
- the position vectors of the pin 43 and the pin 44 which are external force action points are s43 and s44.
- an external force in the lateral direction (Y-axis direction) applied to the bucket 23 is F46
- a position vector of the point of action 46 of the lateral external force is s46.
- ZMP Zero Moment Point
- the ZMP stability criterion is based on the D'Alembert principle. Note that the concept of ZMP and the ZMP stability criterion are described in “LEGGED LOCATION ROBOTS: Miomir Vukobratovic” (“Walking Robot and Artificial Feet: Translated by Ichiro Kato, Nikkan Kogyo Shimbun”).
- the ZMP equation is derived as follows from the balance of moments generated by gravity, inertial force, and external force.
- rzmp ZMP position vector mi: mass of the i-th mass point ri: position vector of the i-th mass point r "i: acceleration vector applied to the i-th mass point (including gravitational acceleration) Mj: j-th external force moment sk: k-th external force action point position vector Fk: k-th external force vector
- mi mass of the i-th mass point
- ri position vector of the i-th mass point
- i acceleration vector applied to the i-th mass point (including gravitational acceleration)
- Mj j-th external force moment
- sk k-th external force action point position vector
- Fk k-th external force vector
- the vector is a three-dimensional vector composed of an X component, a Y component, and a Z component.
- the first term on the left side of the above equation (1) is the sum of moments around the ZMP 70 (see FIG. 3) (radius ri-rzmp) generated by the acceleration component (including gravitational acceleration) applied at each mass point mi. Show.
- the second term on the left side of the above formula (1) indicates the total sum of the external force moments Mj acting on the work machine 1.
- the third term on the left side of the above equation (1) represents the sum of moments around ZMP 70 (radius sk ⁇ rzmp) generated by external force Fk (where the point of action of k-th external force vector Fk is sk).
- Expression (1) is obtained by adding the sum of moments around the ZMP 70 (radius ri-rzmp) generated by the acceleration component (including gravitational acceleration) applied at each mass point mi, the sum of the external force moments Mj, and the external force Fk. It is described that the sum of moments around the ZMP 70 (radius sk ⁇ rzmp) generated by the k-th external force Fk acting point is sk.
- the ZMP 70 on the ground surface 30 can be calculated from the ZMP equation shown in Equation (1).
- ZMP can be treated as a projected point of the center of gravity considering dynamic state and static state, and when ZMP is used as an index, the object is stationary and when it is moving Both can be handled uniformly.
- the calculation unit 60g shown in FIG. 2 mainly includes the link calculation means 60a, the ZMP calculation means 60b, the stability calculation means 60c, the blade contact determination means 60d, and the jack up.
- the functional block of the determination means 60e and the lateral direction external force calculation means 60f is provided.
- Each functional block constituting the calculation unit 60g can be realized by software logic in which each function is incorporated in a program for driving the calculation unit 60g.
- ⁇ Link calculation means > Attitude sensor 3b, turning angle sensor 3s, boom angle sensor 40a, arm angle sensor 41a, bucket angle sensor 42a, lower traveling body acceleration sensor 2a, upper turning shown in FIG. 1 and FIG. Detection values of the body acceleration sensor 3a, the boom acceleration sensor 10a, the arm acceleration sensor 12a, and the pin force sensors 43a and 44a are sent to the link calculation means 60a.
- the link calculation means 60a of the calculation unit 60g the value of the attitude sensor 3b provided in the upper swing body 3 shown in FIG. 1 and the swing angle sensor 3s, the boom angle sensor 40a, and the arm angle sensor 41a provided in each part of the work machine 1 are shown.
- the kinematics calculation is sequentially performed using the detection value of the bucket angle sensor 42a. Then, the position vectors r2, r3, r10, r12 of the mass points 2P, 3P, 10P, 12P shown in FIG. 3, the lower traveling body acceleration sensor 2a, the upper turning body acceleration sensor 3a, the boom acceleration sensor 10a, and the arm acceleration sensor 12a.
- the external force vectors F43, F44, F46 acting on the pins 43, 44 are converted into values based on the machine reference coordinate system (O-XYZ).
- O-XYZ machine reference coordinate system
- a kinematic calculation method for example, a method described in “Robot Control Basics: Yoshikawa Tsuneo, Corona (1988)” which is a non-patent document can be used.
- the ZMP calculation means 60b of the calculation unit 60g shown in FIG. 2 calculates the coordinates of the ZMP 70 shown in FIG. 4 using the position vector, acceleration vector, and external force vector of each mass point converted into the machine reference coordinate system.
- Equation (1) is solved under such conditions, and the X coordinate rzmpx of the ZMP 70 is calculated as follows.
- the Y coordinate rzmpy of the ZMP 70 is calculated as follows.
- m is the mass of each mass point 2P, 3P, 10P, 12P shown in FIG. 3, and the mass m2, m3, m10, m12 of each mass point is substituted.
- R ′′ is the acceleration of each mass point, and the accelerations r ′′ 2, r ′′ 3, r ′′ 10, r ′′ 12 of each mass point are substituted.
- S indicates the position vector of the pins 43 and 44 which are external force application points and the lateral external force application point 46 of the bucket 23, and s43, s44 and s46 are substituted.
- F represents an external force vector applied to the pins 43 and 44 which are external force application points and the lateral external force application point 46 of the bucket 23, and F43, F44 and F46 are substituted.
- the ZMP computing unit 60b can calculate the coordinates of the ZMP 70.
- the stability calculation unit 60c determines the stability of the work machine 1 based on the coordinates of the ZMP 70 (X coordinate: 70x, Y coordinate: 70y) calculated by the ZMP calculation unit 60b. As described above, when the ZMP 70 exists inside the support polygon L formed by the ground contact point between the work machine 1 and the ground surface 30, the work machine 1 shown in FIG. 1 performs work without falling. be able to.
- the stability calculating means 60c in the first embodiment calculates the support polygon L as shown in FIG. 4 (a) or (b) formed by the work machine 1 and the ground surface 30, and For the support polygon L, a normal region J having a sufficiently low possibility of falling and a fall warning region N having a higher possibility of falling are set.
- the stability calculation means 60c outputs information on stability to the display device 61.
- the stability calculation means 60c outputs stability information and a fall warning to the display unit 61 and the alarm device 63.
- the operator can know the possibility of the fall before the ZMP 70 reaches the support polygon L.
- FIG. 4 is a diagram illustrating the support polygon L and the ZMP 70.
- FIG. 4A is a diagram illustrating an example of the support polygon in a state where the lower traveling body is upright on the ground surface. These are figures which show an example of a support polygon in the state where the lower traveling body was jacked up by the work front.
- FIG. 4 shows an image displayed on the display device 61 (see FIG. 1) provided in the driver's seat 4 (see FIG. 1), and the surrounding double line shows a frame of the display device 61.
- the support polygon L when the work machine 1 is upright on the ground surface 30, the support polygon L is substantially equal to the planar shape of the lower traveling body 2. Therefore, when the planar shape of the lower traveling body 2 is rectangular, the support polygon L is rectangular as shown in FIG. As shown in FIG. 5, the support polygon L when the lower traveling body 2 has a crawler has a line connecting the center points of the left and right sprockets 32 as a front boundary line and a center point of the left and right idlers 33. The connected line is a quadrangle with the rear boundary line and the left and right track link outer ends at the left and right boundary lines. The front and rear boundaries may be the ground contact points of the foremost lower roller 34 and the rearmost lower roller 34.
- the work machine 1 jacks the tip of the work front 6 and the rear part of the lower traveling body 2 (the work front 6 is jacked in front of the lower traveling body 2).
- the support polygon L becomes a polygon as shown in FIG. 4B.
- the calculation of the support polygon L is performed based on the contact state of the work machine 1 with reference to the determination result of the blade contact determination unit 60d or the jackup determination unit 60e.
- the boundary K between the normal region J and the fall warning region N is set inside the support polygon L.
- the boundary K is a polygon that is reduced to the center point side according to the ratio determined by the support polygon L according to the safety factor, or the length that is determined by the support polygon L according to the safety factor. Set as a polygon moved inward.
- the size of the fall warning area N may be determined in consideration of the safety required of the work machine 1.
- the safety factor may be a predetermined value (for example, 80%) set in advance, and may be changed depending on the proficiency level of the operator who operates the work machine 1, the work content, the road surface, the surrounding conditions, and the like. It may be a value. In this case, a configuration in which the safety factor is automatically set from information given in advance, output values of various sensors, or a configuration in which the operator or work manager arbitrarily sets the safety factor using the user setting input device 55 is conceivable.
- the said safety factor may be changed during work according to the work state of the work machine 1, and it is good also as a structure which uses a different value about front, back, left, and right.
- the ZMP 70 tends to move to the valley side of the inclined surface, and tends to easily fall to the valley side compared to the mountain side. Therefore, according to the inclination angle, as shown in FIG. 6A, the fall warning area N is set so that the valley side becomes wider.
- a method of using the detected value of the attitude sensor 3b in addition to the input by the operator is conceivable as the inclination angle.
- the fall warning area N may be set so that the direction other than the direction of the work front 6 becomes wider according to the direction of the work front 6.
- the direction of the work front 6 with respect to the support polygon L can be detected by the turning angle sensor 3s.
- Fig. 7 shows an example of setting the fall warning area N in consideration of the work situation and the surrounding situation.
- the work machine 1 is parked on a gentle slope with the mountain side as the front, workers are present behind the work machine 1 and the left rear, and a truck is present on the left side.
- the fall warning area N is set wider in the direction of the groove than the front where there is nothing, In the direction in which there is a fall, the fall warning area N is set to be wider. Further, the fall warning area on the valley side (rear side) where the fall is likely to occur is set to be wide.
- a lever operation amount sensor 51 for detecting an input command amount to each of the drive actuators 11, 13, and 15 is installed, and a work front posture calculated by the ZMP calculation means, a bucket external force, and a history of detection values of the lever operation amount sensor 51 are used.
- the closest one of the preset operation patterns is selected, and the corresponding fall warning area N is output.
- the safety factor may be changed depending on the intensity of exercise of the work machine 1. While the work machine 1 is operating, the influence of the moment term due to the inertial force of the ZMP equation shown in Expression (1) increases, and the displacement amount of the ZMP 70 increases. That is, when the work machine 1 is operating in some manner, the ZMP 70 is likely to reach the support polygon L, and the possibility of falling is high. Therefore, by changing the size of the fall warning area N in accordance with the motion state of the work machine 1, when the work machine 1 is moving violently, the fall warning is output quickly.
- the sum of the momentum of each mass point is used as an index for evaluating the intensity of the motion state of the work machine 1. That is, the masses m2, m3, m10, and m12 of the mass points 2P, 3P, 10P, and 12P set as shown in FIG. 3 and the acceleration sensors (the lower traveling body acceleration sensor 2a and the upper turning body acceleration) shown in FIG.
- the speeds r′2, r′3, r′10, r′12 of the mass points calculated from the integral values of the values of the sensor 3a, the boom acceleration sensor 10a, the arm acceleration sensor 12a) or the differential values of the values of the angle sensors; Is the sum of the absolute values of the products of
- region N is determined from the magnitude
- the maximum value of the momentum is calculated from the cylinder speed determined by the performance of the work machine 1.
- the maximum position of the boundary K is a position where the support polygon L is moved inward by an amount corresponding to the safety margin considering the measurement accuracy and the driver's reaction delay.
- the minimum position of the boundary K is a position where the support polygon L is moved inward so as to be sufficiently safe even when moving at the maximum speed. Then, the maximum and minimum positions of the boundary K are interpolated with a straight line, and the boundary K is gradually set inward as the momentum of the work machine increases.
- a curve combining a parabola and an arc may be used for the interpolation between the maximum position and the minimum position of the boundary K.
- the sum of the kinetic energy of each mass point may be used as an index for evaluating the intensity of the motion status of the work machine 1 that changes the fall warning area N. That is, the sum of the products of the masses m2, m3, m10, m12 of the mass points 2P, 3P, 10P, 12P shown in FIG. 3 and the squares of the velocities r′2, r′3, r′10, r′12. In terms of the formula,
- the stability determination using the ZMP 70 is performed regardless of the operation of the work machine 1, the assignment operation to the expressions (3) and (4) and the assignment operation result. This can be done by comparison with a predetermined area. Therefore, it is not necessary to set up a complicated model, and stability can be calculated by performing the same calculation in any operation. Therefore, calculation and determination of stability can be performed every moment regardless of the type of operation. There is an excellent effect that it is possible.
- the lateral external force calculation means 60f calculates an external force F46 (see FIG. 5) applied to the bucket 23 in the Y-axis direction.
- the acting point of the external force in the Y-axis direction is defined as a lateral direction external force acting point 46. Since it is difficult to directly measure the external force vector F46 applied to the lateral external force acting point 46, the swing motor 7 detected by the swing motor pressure sensors 7i and 7o provided in the swing motor 7 in the lateral external force calculation means 60f. Is calculated using the pressure value of the hydraulic pressure that drives.
- the lateral external force calculation means 60f uses a model as shown in FIG.
- FIG. 5 is a top view showing modeling of the upper-part turning body according to the first embodiment.
- the swing torque Tz3 applied to the upper swing body 3 is calculated from the hydraulic pressure difference between the suction side hydraulic pressure detected by the swing motor pressure sensor 7i and the discharge side hydraulic pressure detected by the swing motor pressure sensor 7o. .
- the lateral external force vector F46 calculated in this way acts on the lateral external force application point 46 of the bucket 23 shown in FIG. 3 to generate a moment.
- the blade contact determination means 60d determines whether or not the blade 18 is in contact with the ground surface 30.
- the lower traveling body 2 of the work machine 1 according to the first embodiment includes a blade 18, and the shape of the support polygon L changes depending on the ground contact state of the blade 18. More specifically, the support polygon L has a shape including the bottom of the blade as shown in FIG. 8 when the blade 18 contacts the ground, and the support polygon L is deformed so as to expand. Therefore, in order to determine the stability more accurately, it is necessary to change the shape of the support polygon L used for setting the fall warning region N in the stability calculation means 60b.
- the blade contact determination means 60d determines the contact state of the blade 18 using the values Pb1 and Pb2 of the blade cylinder pressure sensors 19i and 19o that measure the suction side pressure and the discharge side pressure of the hydraulic pressure that drives the blade cylinder 19. To do.
- a threshold value Pb3 that is larger than the pressure necessary for driving the blade 18 in the unloaded state and smaller than the pressure necessary for jacking up the work machine 1 is set, and Pb1 ⁇ Pb2 that is the difference between Pb1 and Pb2 is greater than the threshold value Pb3.
- the stability calculation means 60c receives the signal from the blade contact determination means 60d and changes the shape of the support polygon L so as to expand as shown in FIG.
- the jack-up determination means 60e is in a jack-up state based on the detected value of the attitude sensor 3b of the upper swing body 3, the detected value of the swing angle sensor 3s, and the detected values of the pin force sensors 43a and 44a installed on the pins 43 and 44. Determine the presence or absence.
- the grounding point of the work machine 1 and the ground surface 30 changes, so that the shape of the support polygon L Changes. That is, the supporting polygon L is defined by the two end points on the grounding side of the lower traveling body 2 and the grounding point of the bucket 23 as shown in FIG. It becomes a polygon to be formed. Since the shape of the support polygon L changes discontinuously in this way, in the jack-up state, there is a possibility of falling even if the ZMP 70 exists within the rectangular range as shown in FIG. is there. Therefore, in order to accurately determine the stability, it is necessary to detect the jack-up state and change the support polygon L used for setting the fall warning region N in the stability calculation means 60c.
- the jack-up determination means 60e is such that the value of the posture sensor 3b changes in a direction in which the work front 6 side is lifted, and the force acting on the bucket 23 calculated by the pin force sensors 43a and 44a pushes the ground surface 30. In this case, it is determined that the jack is up, and a signal is transmitted to the stability calculation means 60c. In the jack-up operation, which part of the lower traveling body 2 is lifted depends on the contact position of the bucket 23.
- FIG. 9 is a diagram showing the relationship between the direction of the work front 6 and the support polygon L.
- the front of the lower traveling body 2 is levitated, and the support polygon L is formed by the rear end point of the lower traveling body 2 and the grounding point of the bucket 23. It becomes a square.
- the rear of the lower traveling body 2 is levitated, and the support polygon L is formed by the front end point of the lower traveling body 2 and the grounding point of the bucket 23. Will be a polygon.
- the support polygon L is the left or right end point of the lower traveling body 2 and the bucket. It becomes a polygon formed by 23 grounding points.
- the support polygon L is a polygon formed by the left end point of the lower traveling body 2 and the contact point of the bucket 23.
- the ZMP 70 is connected to the right rear side of the line segment connecting the end point of the lower traveling body 2 farthest from the grounding point of the bucket 23 (the left rear end point of the lower traveling body 2) and the grounding point of the bucket 23.
- the end point on the right rear is grounded, and the front side of the lower traveling body 2 floats, so that the support polygon L is formed by the front end point of the lower traveling body 2 and the grounding point of the bucket 23. It becomes a polygon.
- the jack-up determination unit 60e determines which part of the lower traveling body 2 is levitated and which part is grounded when the jack-up state is detected.
- the shape of the support polygon L is calculated, and a signal is transmitted to the stability calculation means 60c.
- the kinematic calculation is sequentially performed using the detection values of the turning angle sensor 3s, the boom angle sensor 40a, the arm angle sensor 41a, and the bucket angle sensor 42a, and the grounding point of the bucket 23 is calculated.
- a bucket contact center point is calculated from the calculated bucket contact point, and an end point farthest from the bucket contact center point among the end points of the lower traveling body 2 is set as a first contact end point.
- the line segment connecting the first grounding end point and the bucket grounding center point is compared with the ZMP 70, and the end point on the side where the ZMP 70 exists is selected as the second grounding point out of the two end points adjacent to the first grounding end point.
- a polygon connecting the first and second grounding end points and the grounding point of the bucket 23 is defined as a support polygon L.
- the inclination of the lower traveling body 2 is calculated using the detected values of the attitude sensor 3b and the turning angle sensor 3s, and the valley side 2 of the end points of the lower traveling body 2 is calculated. You may comprise so that a point may be selected as a grounding end point.
- the stability calculating means 60c changes the shape of the support polygon L in response to the signal from the jack-up determining means 60e.
- the work machine 1 includes a display device 61 and an alarm device 63.
- the display device (display means) 61 is a device composed of a cathode ray tube, a liquid crystal panel, or the like, and is provided in the cab 4 (see FIG. 1).
- the support polygon L calculated by the control device 60 and the fall warning area N are provided.
- ZMP coordinates (see FIG. 4), etc. are displayed.
- the display device 61 may be configured to display a sign of a fall warning.
- the operator can always recognize the possibility of the fall, so that it is possible to perform highly safe work.
- the display device 61 may be configured to also serve as a user setting input device 55 for an operator to set a fall warning area, a warning method, and the like.
- the display device 61 has input means such as a touch panel, and displays a setting input icon.
- an alarm device (alarm means) 63 is provided in the cab 4.
- the alarm device 63 is a device that generates a warning sound, such as a buzzer, for example.
- a warning sound such as a buzzer
- the alarm issued by the alarm device 63 provided in the cab 4 allows the operator to recognize the possibility of falling, so that it is possible to perform highly safe work.
- the mass of the fuel such as the operator and light oil is set to a standard constant value and included in the mass of the upper swing body 3.
- the mass and the center of gravity of the upper swing body 3 are changed according to the mass of the operator and the fuel. You may do it.
- the operator's mass may be measured automatically by installing a scale in the driver's seat 4 or may be input by the operator using the user setting input device 55. Also, a method of calculating the mass of the fuel by multiplying the specific gravity of the fuel to be used by the remaining amount of fuel detected by the fuel gauge can be considered.
- the operation lever is usually provided at an operation place of the operator other than on the work machine 1.
- a display device and an alarm device may also be installed at a place where an operator operates.
- the display device there may be a case where the work manager confirms the status of the work machine 1 from a remote place.
- a manager display device is provided in a place other than on the work machine 1 and the status of the work machine 1 is displayed by performing data transfer using wireless or the like. be able to.
- the display of the manager display device may be the same as that for the driver, or may be displayed with other information added.
- dynamic stability including inertia force and external force of the work front is calculated every moment, regardless of the operation of the work machine 1, and information on stability is obtained. Can be presented to the driver without delay. As a result, it is possible to provide a highly safe work machine by reducing the possibility that the work machine will fall due to an unreasonable operation.
- the stability can be judged accurately even when the grounding condition changes. Therefore, safety can be improved.
- the turning angle includes a method of measuring an absolute azimuth with respect to the ground surface 30 and a method of measuring a relative angle with respect to the lower traveling body 2.
- the relative angle is detected by the turning angle sensor 3s.
- the absolute azimuths of the upper turning body 3 and the lower traveling body 2 are detected by using a geomagnetic sensor, GPS, and the like. It is good also as a structure which calculates a relative turning angle. By adopting such a configuration, the present invention can be implemented even when it is difficult to install the turning angle sensor 3s.
- the boom angle sensor 40a and the arm angle sensor 41a are used for detecting the posture of the work front 6.
- a tilt angle sensor may be used instead of these angle sensors.
- the upper turning body acceleration sensor 3a, the boom acceleration sensor 10a, and the arm acceleration sensor 12a are used to calculate the acceleration of each of the mass points 3P, 10P, and 12P shown in FIG.
- the acceleration may be obtained by second-order differentiation of the value of the angle sensor.
- the rotational acceleration of the upper swing body 3 may be determined by second-order differentiation of the rotation angle of the upper swing body 3 detected by the swing angle sensor 3s.
- it is necessary to pay attention to measurement noise due to second-order differentiation but the number of sensors to be installed can be reduced, and signals to be transmitted to the control device 60 are reduced. Therefore, a cheaper and simpler configuration can be obtained.
- the attitude sensor 3 b is installed on the upper swing body 3, but may be installed on the lower traveling body 2. With such a configuration, the inclination of the machine reference coordinate system with respect to the world coordinate system can be calculated without using the detection value of the turning angle sensor 3s.
- the posture sensor 3b of the upper-part turning body 3 is used to detect the inclination of the road surface, but an acceleration sensor capable of measuring a direct current component (gravity) is used as the lower traveling body acceleration sensor 2a.
- the posture sensor 3b may be omitted. In such a case, since the number of sensors to be installed is reduced and the number of signals to be transmitted to the control device 60 is reduced, a cheaper and simpler configuration can be achieved.
- ⁇ Without attitude sensor> For example, when the site where the work machine 1 is used is limited to a horizontal site, such as scrap processing work in a stationary yard, the position vector r of each mass point due to the inclination of the work machine 1 and the external force acting point position vector The change of s is sufficiently small.
- the posture sensor 3b of the upper swing body 3 may be omitted.
- the configuration is cheaper and simpler.
- the ZMP 70 may be calculated assuming that the machine reference coordinate system is always horizontal with respect to the world coordinate system.
- the acceleration of the lower traveling body 2 is estimated from the acceleration of the upper swing body 3 and the turning angle detected by the turning angle sensor 3s, and the lower traveling body acceleration sensor 2a that detects the acceleration of the lower traveling body 2 is provided. It is good also as a structure which does not provide.
- the lower traveling body acceleration sensor 2a of the lower traveling body 2 is provided. There may be no configuration.
- the acceleration r′2 of the lower traveling body 2 may be calculated as the ZMP 70 only as a gravity component.
- the presence / absence of blade contact may be input by the operator using the user setting input device 55, and the blade cylinder pressure sensors 19i and 19o may not be provided.
- the upper swing body 3 swings 360 degrees or more with respect to the lower travel body 2, and therefore when the sensor is disposed on the lower travel body 2, the upper swing body 3 slips to transmit the detection value of the sensor to the control device 60. It is necessary to use a ring or radio. In the case where the lower traveling body acceleration sensor 2a and the blade cylinder pressure sensors 19i and 19o are not provided as described above, there is no need to transmit information using a slip ring, radio, etc., and a simpler and more reliable configuration It can be. In addition, since the number of sensors to be installed is reduced and the number of signals to be transmitted to the control device 60 is reduced, a cheaper and simpler configuration can be achieved.
- the upper swing body acceleration sensor 3a of the upper swing body 3 may not be provided. In such a case, since the number of sensors to be installed is reduced and the number of signals to be transmitted to the control device 60 is reduced, the configuration is cheaper and simpler.
- the acceleration r ′′ 3 of the upper swing body 3 may be calculated as the ZMP 70 only as a gravity component.
- ⁇ No external force detection means> For example, when the work machine 1 is equipped with a cutter (not shown) as a work tool and mainly performs a cutting operation, the cutting operation is performed using the internal force of the cutter. Don't join. Therefore, there is no possibility that the stability will be deteriorated by an external force during the work. In such a case, the pin force sensors 43a and 44a for detecting the external force acting on the pins 43 and 44 (see FIG. 1) are not provided. Also good.
- the work tool may be provided with an acceleration sensor, and the ZMP calculation may be performed based on the gravity applied to the work machine 1 and the inertial force applied to the work tool.
- FIG. 10 is a schematic side view showing a work machine according to the second embodiment
- FIG. 11 is a top view showing the upper swing body according to the second embodiment as a model.
- the same components as those in the first embodiment are denoted by the same reference numerals, and description thereof is omitted.
- the second embodiment is different from the first embodiment in that a swing mechanism that swings left and right is provided between the upper swing body 3 and the boom 10. In the following, differences from the first embodiment will be mainly described.
- the upper swing body 3 is turnably attached to the lower traveling body 2, and the upper swing body 3 is driven by the swing motor 7.
- the cab 4 and the counterweight 8 are attached to the upper swing body 3.
- a swing post 24 is provided in front of the upper swing body 3 so as to be swingable left and right at a fulcrum 45.
- the swing post 24 is connected to the upper swing body 3 and the swing post 24 (see FIG. 11).
- the work machine 1a includes a control device 80 that controls the entire work machine 1a.
- the swing post 24 is provided with a boom 10 that can swing up and down at a fulcrum 40, and the boom 10 is provided with an arm 12 that can swing at a fulcrum 41. Further, the arm 12 is provided with a bucket 23 that is rotatable at a fulcrum 42. And the work front 6 is comprised by the boom 10 and the arm 12 similarly to 1st Embodiment.
- a boom cylinder 11 for driving the boom 10 is provided and connected to the swing post 24 and the boom 10.
- the arm 12 is driven by the arm cylinder 13 and the bucket 23 is driven by the work tool cylinder 15.
- the upper swing body 3 is provided with an operator's cab 4 for operating the work machine 1a.
- the operating device 50, the display device 61, and the alarm device 63 are provided as in the first embodiment. Is provided.
- the work machine 1a includes a turning angle sensor 3s, a posture sensor 3b, a boom angle sensor 40a, an arm angle sensor 41a, a bucket angle sensor 42a, a lower traveling body acceleration sensor 2a, and an upper turning body acceleration.
- a sensor 3a, a boom acceleration sensor 10a, and an arm acceleration sensor 12a are provided.
- a swing angle sensor 45 a for detecting the rotation angle of the swing post 24 is provided at the fulcrum 45 of the upper swing body 3 and the swing post 24.
- swing pressure sensors 25 i and 25 o for detecting the suction side pressure and the discharge side pressure are provided on the suction side and the discharge side of the hydraulic pressure that drives the swing post cylinder 25.
- FIG. 12 is a schematic configuration diagram of a control device provided in the work machine according to the second embodiment.
- the functional blocks of the control device 80 shown in FIG. 10 those equivalent to the functional blocks of the control device 60 according to the first embodiment are denoted by the same reference numerals, and description thereof is omitted.
- the swing torque Tz45 applied around the fulcrum 45 of the swing post 24 is calculated from the pressure difference between the suction side pressure and the discharge side pressure detected by the swing pressure sensors 25i and 25o provided in the swing cylinder 25.
- a link calculation is performed using the detected values of the swing angle sensor 45a, the boom angle sensor 40a, the arm angle sensor 41a, and the bucket angle sensor 42a (see FIG. 10) provided on the work front 6, thereby supporting the fulcrum 45 of the swing post 24. From the above, a distance vector l to the lateral external force acting point 46 of the bucket 23 is calculated.
- ⁇ Link calculation means> As shown in FIG. 10, the posture sensor 3b, the turning angle sensor 3s, the swing angle sensor 45a, the boom angle sensor 40a, the arm angle sensor 41a, the bucket angle sensor 42a, and the lower traveling body acceleration sensor arranged in each part of the work machine 1a. 2a, each kinematic position vector by performing kinematic calculation sequentially using the values of the upper turning body acceleration sensor 3a, the boom acceleration sensor 10a, the arm acceleration sensor 12a, the pin force sensors 43a and 44a, and the lateral external force vector F46.
- the stability calculation means 60c uses the result of the link calculation, calculates the ZMP coordinates in the same manner as in the first embodiment, and performs stability determination.
- various sensors can be changed or deleted as in the first embodiment.
- the structure which is not provided with the upper revolving body 3 may be sufficient.
- FIG. 13 is a schematic side view showing the work machine in the third embodiment
- FIG. 14 is a top view showing the upper swing body according to the third embodiment as a model.
- symbol is attached
- the third embodiment differs from the first embodiment in that it has an offset mechanism that translates the tip from the arm 12 of the work front 6 to the left and right as a left-right swing mechanism. In the following, differences from the first embodiment will be mainly described.
- the work machine 1 b according to the third embodiment is mainly configured by a lower traveling body 2, an upper swing body 3, and a swing motor 7 that drives the upper swing body 3.
- the upper swing body 3 is provided with a cab 4, a counterweight 8, and the like.
- the control apparatus 90 which controls the whole working machine 1b is provided.
- the work front 6 includes a boom (lower boom) 10 provided on the upper swing body 3 so as to be swingable up and down, an upper boom 26 provided on the distal end side of the boom 10, an arm support 28 provided on the distal end side of the upper boom 26, An arm 12 swingably attached to the distal end side of the arm support 28, a bucket 23 pivotally attached to the distal end side of the arm 12, and a link rod 29 connecting the boom 10 and the arm support 28.
- the rotation angle of the work front 6 at the fulcrum 47 between the boom 10 and the upper boom 26 and the fulcrum 48 between the upper boom 26 and the arm support 28 is changed by the offset cylinder 27. 26 is translated (offset) in the left-right direction with respect to the lower boom 10.
- the work machine 1b according to the third embodiment swings the cylinders of the work tools such as the boom 10, the arm 12, and the bucket 23 with the work front 6 being offset as described above, for example, on the roadside. Excavation work such as side grooves is performed.
- the upper swing body 3 is provided with an operator's cab 4 for operating the work machine 1b.
- the operating device 50 the display device 61, and an alarm are provided.
- a device 63 is provided.
- the work machine 1b includes a turning angle sensor 3s, a posture sensor 3b, a boom angle sensor 40a, an arm angle sensor 41a, a bucket angle sensor 42a, a lower traveling body acceleration, as in the first embodiment.
- a sensor 2a, an upper turning body acceleration sensor 3a, a boom acceleration sensor 10a, and an arm acceleration sensor 12a are provided.
- the offset fulcrum 48 is provided with an offset angle sensor 48 a for detecting the rotation angle at the fulcrum 48.
- offset pressure sensor ⁇ Offset pressure sensor> Further, the offset cylinder 27 is provided with offset pressure sensors 27 i and 27 o for detecting the suction side pressure and the discharge side pressure of the hydraulic pressure that drives the offset cylinder 27.
- FIG. 15 is a schematic configuration diagram of a control device provided in the work machine according to the third embodiment.
- the functional blocks of the control device 90 shown in FIG. 15 those equivalent to the functional blocks of the control device 60 according to the first embodiment are denoted by the same reference numerals, and description thereof will be omitted as appropriate.
- ⁇ Lateral force calculation means> The lateral external force applied to the bucket 23 shown in FIG. 14 is difficult to directly measure, and is thus calculated from the suction side pressure and the discharge side pressure of the hydraulic pressure that drives the offset cylinder 27. More specifically, the model shown in FIG. 14 is used.
- the oscillation torque Tz48 applied around the offset fulcrum 48 is calculated from the pressure difference between the suction side pressure and the discharge side pressure detected by the offset pressure sensors 27i and 27o provided in the offset cylinder 27.
- link calculation is performed using the detected values of the boom angle sensor 40a, arm angle sensor 41a, bucket angle sensor 42a, and offset angle sensor 48a (see FIG. 13) provided on the work front 6, and the bucket 23 from the offset fulcrum 48 is obtained.
- the distance vector l to the lateral external force acting point 46 is calculated.
- ⁇ Link calculation means> As shown in FIG. 13, the posture sensor 3b, the turning angle sensor 3s, the boom angle sensor 40a, the arm angle sensor 41a, the bucket angle sensor 42a, the offset angle sensor 48a, and the lower traveling body acceleration sensor, which are arranged in each part of the work machine 1b.
- Position vectors r2, r3, r10, r12, mass point acceleration vectors r ′′ 2, r ′′ 3, r ′′ 10, r ′′ 12, external force action point position vectors s43, s44, external force vectors F43, F44 , F46 are converted into values based on the machine reference coordinate system (O-XYZ).
- the stability calculation means 60c calculates the ZMP coordinates in the same manner as in the first embodiment, using the result of the link calculation, and performs stability determination.
- various sensors can be changed or deleted as in the first embodiment.
- the structure which is not equipped with the upper turning body 3 may be sufficient.
- dynamic stability including the inertial force and external force of the working front during operation can be calculated momentarily and presented to the operator without delay. It becomes possible. Therefore, it is possible to reduce the possibility of the work machine falling over by an unreasonable operation, and to provide a work machine with high safety.
- the stability is accurately determined even when the grounding status changes. It is possible to improve safety.
- FIG. 16 is a schematic side view showing a work machine according to the fourth embodiment
- FIG. 17 is a view showing an example of a support polygon according to the fourth embodiment.
- the same components as those in the first embodiment are denoted by the same reference numerals, and description thereof is omitted.
- the fourth embodiment is different from the first embodiment in that the traveling portion of the lower traveling body 2 has wheels. In the following, differences from the first embodiment will be mainly described.
- the work machine 1 c according to the fourth embodiment is mainly configured by a lower traveling body 2, an upper swing body 3, an upper swing body 3, and a swing motor 7 that drives the upper swing body 3. .
- the upper swing body 3 is provided with a driver's seat 4, a counterweight 8, and the like.
- the control apparatus 90 which controls the work machine 1c whole is provided.
- the lower traveling body 2 includes a wheel 35, an outrigger 36, an outrigger cylinder 37, a frame that supports them, an axle, and the like.
- the outrigger 36 is driven by an outrigger cylinder 37.
- the configuration of the work front 6 is the same as that of the first embodiment.
- an operating device 50, a display device 61, and an alarm device 63 are provided as in the first embodiment.
- the work machine 1c includes a turning angle sensor 3s, a posture sensor 3b, a boom angle sensor 40a, an arm angle sensor 41a, a bucket angle sensor 42a, a lower traveling body acceleration sensor, as in the first embodiment. 2a, an upper turning body acceleration sensor 3a, a boom acceleration sensor 10a, and an arm acceleration sensor 12a are provided.
- Control device 60 The basic configuration of the control device 60 is the same as that of the first embodiment shown in FIG. Description of functional blocks of the control device 60 that are equivalent to those of the first embodiment is omitted.
- the stability calculation unit 60c performs stability determination based on the coordinates of the ZMP 70 calculated by the ZMP calculation unit 60b.
- the stability calculation means 60c calculates a support polygon L formed by the work machine 1 and the ground surface 30, and the support polygon L has a sufficiently low normal area J and a possibility of falling.
- the fall warning region N having higher characteristics is set and the coordinates of the ZMP 70 are in the normal region J
- information regarding stability is output to the display device 61.
- the stability calculation means 60c outputs stability information and a fall warning to the display unit 61 and the alarm device 63.
- FIG. 17 is a diagram showing an example of the support polygon L in the fourth embodiment.
- the support polygon L when all the front, rear, left and right outriggers 36 are grounded is a quadrilateral connecting the grounding points of the front, rear, left and right outriggers 36.
- the support polygon L when rocking when rocking, it is a quadrilateral connecting the outrigger grounding point directly below the rocking center line of the outrigger grounding surface, and when having a fixed type outrigger, A quadrilateral connecting the points farthest from the center of the outrigger ground plane.
- a support polygon L is formed by connecting the grounding points of the front, rear, left and right wheels 35 as shown in FIG. Further, in the wheel type work machine having no outrigger, the support polygon L is the same as that in FIG.
- the support polygon L is the grounding point of the grounded outrigger 36 and A quadrangular shape connecting the grounding points of the wheels 35 in the direction in which the outriggers are not grounded.
- whether or not the outrigger 36 is in contact with the ground may be changed based on an operator setting, or may be determined automatically.
- a posture sensor is installed in each outrigger or each outrigger cylinder 37, and a method of determining the presence or absence of installation from the posture of the outrigger or a pressure sensor is installed in each outrigger cylinder 37.
- a method of determining the presence / absence of installation from the pressure detection value is conceivable.
- the boundary K between the normal region J and the fall warning region N is set inside the support polygon L.
- the boundary K is determined in the same manner as in the first embodiment.
- various sensors can be changed or deleted as in the first embodiment.
- the structure which is not provided with the upper revolving body 3 may be sufficient.
- the stability determination condition is changed in accordance with the operating state of the work machine, and the changed stability determination condition is changed.
- the stability of the work machine can be determined based on the above. In other words, the driver can check the stability every moment corresponding to the operating state of the work machine, and has an excellent effect that the work can be performed with high safety.
- a hydraulic excavator has been described as an example of the work machine 1, but the present invention can be applied to any work machine having a traveling body and a work front.
- the concentrated mass point model is used as the model for calculating the ZMP 70.
- the model may be implemented based on another modeling form such as a rigid body model.
- the work front 6 is provided directly on the lower traveling body 2.
- the posture sensor 3b is provided in the lower traveling body 2, and the turning angle sensor 3s and the upper turning body acceleration sensor 3a are not provided.
Landscapes
- Engineering & Computer Science (AREA)
- Mining & Mineral Resources (AREA)
- Civil Engineering (AREA)
- General Engineering & Computer Science (AREA)
- Structural Engineering (AREA)
- Mechanical Engineering (AREA)
- Component Parts Of Construction Machinery (AREA)
- Operation Control Of Excavators (AREA)
Abstract
Description
以下、本発明の第1の実施形態について説明する。
<本体>
図1は、第1の実施形態にかかる作業機械を示す概略側面図である。第1の実施形態にかかる作業機械1は、下部走行体2に上部旋回体3が旋回可能に取付けられ、上部旋回体3は旋回モータ7によって旋回駆動される。上部旋回体3には、運転室4、エンジン5が取付けられている。また、上部旋回体3の後方には、カウンタウエイト8が取り付けられている。このほかに、作業機械1の全体を制御する制御装置60が備わって、作業機械1が構成される。
上部旋回体3には、支点40を関節として上下揺動自在にブーム10が設けられており、ブーム10の先端には、支点41を関節として揺動自在にアーム12が設けられている。さらに、アーム12の先端には、支点42を関節として回動自在に作業具としてのバケット23が設けられる。ここで、前記ブーム10、アーム12により作業フロント6が構成される。
上部旋回体3には、作業機械1を操作するオペレータ用の運転室4が備わり、運転室4の中には、オペレータからの各駆動アクチュエータに対する動きの指示を入力するための操作装置50、後述する支持多角形やZMP座標等を表示する表示装置(表示手段)61、作業機械1の転倒警告音等を発する警報装置(警報手段)63、オペレータが各種設定を行うためのユーザ設定入力装置55などが設けてある。
下部走行体2の前面には、上下揺動自在にブレード18が設けてあり、ブレード18はブレードシリンダ19により駆動される。
<姿勢センサ>
上部旋回体3には、後述する重力と逆方向をZ軸としたワールド座標系に対する機械基準座標系の傾きを検出するための姿勢センサ3bが設けられている。姿勢センサ3bは、例えば傾斜角センサであり、上部旋回体3の傾斜角を検出することで、ワールド座標系に対する機械基準座標系の傾きを検出する。
上部旋回体3の旋回中心線3c上には、下部走行体2と上部旋回体3の旋回角度を検出するための旋回角度センサ3sが設けられている。
下部走行体2、上部旋回体3、ブーム10、及びアーム12の重心近傍には、それぞれ下部走行体加速度センサ2a、上部旋回体加速度センサ3a、ブーム加速度センサ10a、アーム加速度センサ12aが設けられている。
アーム12とバケット23を繋ぐピン43、リンク16とバケット23を繋ぐピン44には、それぞれピン力センサ43a、44aが設けられている。ピン力センサ43a、44aは、例えば円筒状の内部にひずみゲージが挿入され、このひずみゲージに発生するひずみを計測することによって、ピン43、44にかかる力(外力)の大きさと方向を検出する。
上部旋回体3を旋回させる旋回モータ7は、旋回モータ7を駆動する油圧の吸入側圧力および吐出側圧力を検出する旋回モータ圧力センサ7iおよび7oを備える。さらに、ブレードシリンダ19には、ブレードシリンダ19を駆動する油圧の吸入側圧力および吐出側圧力を検出するブレードシリンダ圧力センサ19iおよび19oを備える。
図2は、作業機械1が備える制御装置の概略構成図である。制御装置60は、作業機械1の各部に取付けられた各センサからの信号が入力される入力部60h、入力部60hに入力される信号を受けて、所定の演算を行う演算部60g、演算部60gからの出力信号を受けて、作業機械1(図1参照)の安定性情報および転倒警告情報を出力する出力部60iを備える。ここで、表示部61は作業機械1の安定性情報および転倒警告情報を表示し、警報装置63は転倒に関する警報を発する。
図3は制御装置を有するZMP演算用作業機械モデルを示す概略側面図である。重力方向を基準とし、重力と逆方向をZ軸としたワールド座標系(O-XYZ)と下部走行体2を基準とした機械基準座標系(O-XYZ)とを図3に示すように設定する。
また、第1の実施形態では、実装の簡易性を考慮しZMP70を演算するためのモデルとして、図3に示すような各構成部材は、重心に質量が集中している集中質点モデルを用いる。下部走行体2、上部旋回体3、ブーム10、アーム12のそれぞれの質点2P、3P、10P、12Pを各構成部材の重心位置に設定し、それぞれの質点の質量をm2、m3、m10、m12とする。そして、それぞれの質点の位置ベクトルをr2、r3、r10、r12、加速度ベクトルをr´´2、r´´3、r´´10、r´´12とする。
ここで、演算部60gの詳細を説明する前に、第1の実施形態における安定判別方式について説明する。
第1の実施形態においては、作業機械1の安定状態を判定するためにZMP(Zero Moment Point)を用いる。ZMP安定判別規範はダランベールの原理に基づいたものである。なお、ZMPの概念ならびにZMP安定判別規範については「LEGGED LOCOMOTION ROBOTS:Miomir Vukobratovic著(「歩行ロボットと人工の足:加藤一郎訳,日刊工業新聞社」)に記載されている。
ZMP方程式は、重力、慣性力、外力によって発生するモーメントの釣り合いから、以下のように導出される。

rzmp:ZMP位置ベクトル
mi:i番目の質点の質量
ri:i番目の質点の位置ベクトル
r”i:i番目の質点に加わる加速度ベクトル(重力加速度含む)
Mj:j番目の外力モーメント
sk:k番目の外力作用点位置ベクトル
Fk:k番目の外力ベクトル
なお、ベクトルはX成分、Y成分、Z成分で構成される3次元ベクトルである。

前記のようにZMP座標や安定判別を演算するため、図2に示す演算部60gは、主に、リンク演算手段60a、ZMP演算手段60b、安定性演算手段60c、ブレード接地判定手段60d、ジャッキアップ判定手段60e、横方向外力演算手段60fの機能ブロックを備える。この、演算部60gを構成する各機能ブロックは、演算部60gを駆動するプログラムに各機能を組み込んだ、ソフトウェアロジックで実現することができる。
図1および図2に示す、作業機械1の各部に配された姿勢センサ3b、旋回角度センサ3s、ブーム角度センサ40a、アーム角度センサ41a、バケット角度センサ42a、下部走行体加速度センサ2a、上部旋回体加速度センサ3a、ブーム加速度センサ10a、アーム加速度センサ12a、ピン力センサ43a、44aの検出値がリンク演算手段60aに送られる。
図2に示す演算部60gのZMP演算手段60bでは、機械基準座標系に変換された各質点の位置ベクトル、加速度ベクトルおよび外力ベクトルを用いて、図4に示すZMP70の座標を算出する。
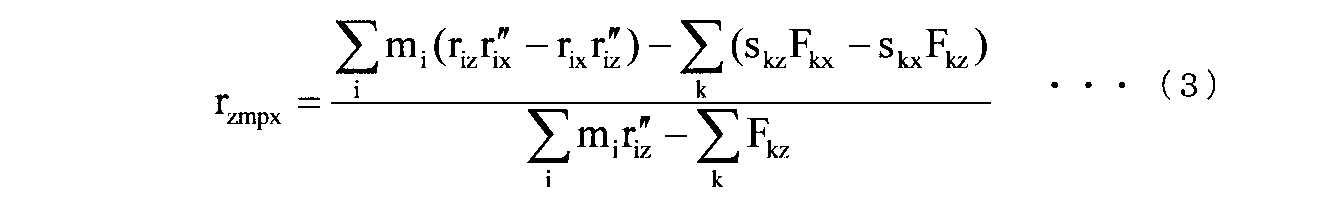
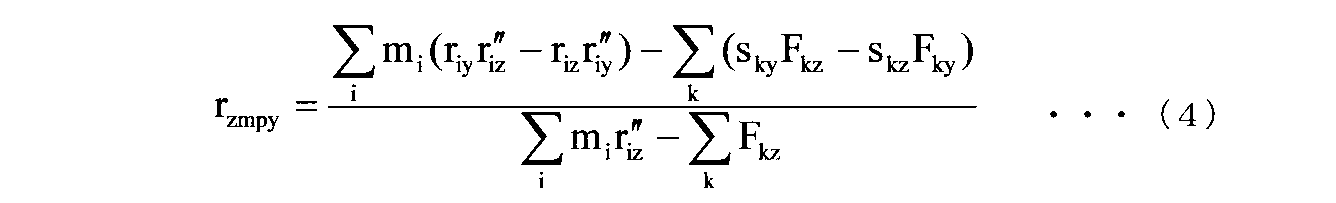
次に、安定性演算手段60cは、ZMP演算手段60bで算出されるZMP70の座標(X座標:70x、Y座標:70y)を基に作業機械1の安定判別を行う。前記のように、ZMP70が、作業機械1と地表面30との接地点によって形成される支持多角形Lの内部に存在する場合、図1に示す作業機械1は転倒することなく、作業を行うことができる。
転倒警告領域Nの設定方法として、現在行っている作業の内容を認識し、その作業内容によって転倒警告領域Nの大きさや形状を変更することが考えられる。
また、作業機械1の運動の激しさによって安全率を変更しても良い。作業機械1が動作している間は、式(1)に示すZMP方程式の慣性力によるモーメント項の影響が大きくなり、ZMP70の変位量が大きくなる。つまり、作業機械1が何らかの動作をしている時のほうが、ZMP70が支持多角形L上まで達しやすく、転倒の可能性が高い。そこで、作業機械1の運動状態に合わせて、転倒警告領域Nの大きさを変化させることによって、作業機械1が激しく運動している場合には、転倒警告を早く出力するようにする。
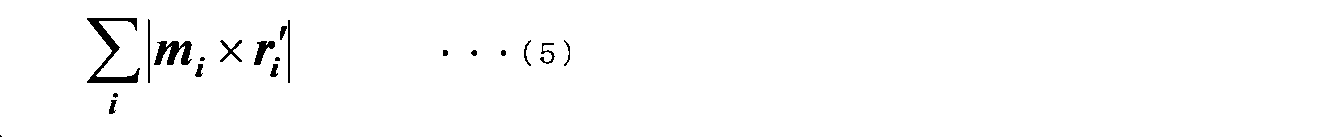
また、転倒警告領域Nを変化させる作業機械1の運動状況の激しさを評価する指標として、各質点の運動エネルギの和を用いてもよい。つまり、図3に示す各質点2P、3P、10P、12Pの質量m2、m3、m10、m12と、速度r´2、r´3、r´10、r´12の平方の積の合計であり、式で表すと、

横方向外力演算手段60fでは、バケット23に加わるY軸方向の外力F46(図5参照)を算出する。Y軸方向の外力の作用点を横方向外力作用点46とする。この横方向外力作用点46に加わる外力ベクトルF46は、直接計測することが困難であるので、横方向外力演算手段60fでは旋回モータ7に設けた旋回モータ圧力センサ7iおよび7oが検出する旋回モータ7を駆動する油圧の圧力値を用いて算出する。このとき、横方向外力演算手段60fは、図5に示すようなモデルを用いる。図5は、第1の実施形態にかかる上部旋回体のモデル化を示す上面図である。
ブレード接地判定手段60dはブレード18が地表面30に接地しているか否かの判定を行う。図1に示すように、第1の実施形態にかかる作業機械1の下部走行体2は、ブレード18を有しており、ブレード18の接地状態によって、支持多角形Lの形状が変化する。より具体的には、支持多角形Lは、ブレード18の接地時には図8に示すようにブレード底部を含む形となり、支持多角形Lは拡大するように変形する。そのため、より正確に安定性を判断するためには、安定性演算手段60bにおいて転倒警告領域Nの設定に用いる支持多角形Lの形状を変化させる必要がある。
ジャッキアップ判定手段60eでは、上部旋回体3の姿勢センサ3bの検出値と旋回角度センサ3sの検出値とピン43、44に設置したピン力センサ43a、44aの検出値をもとにジャッキアップ状態の有無を判断する。
また、図1に示すように、第1の実施形態にかかる作業機械1は、表示装置61及び警報装置63を備える。
さらに第1の実施形態にかかる作業機械1においては、警報装置(警報手段)63が運転室4内に設けられる。警報装置63は、例えばブザーなど、警告音を発生する装置であって、制御装置60で演算した結果、ZMP70が転倒警告領域N(図4参照)にある場合に、安定性演算手段60c(図2参照)からの制御によって警告音などの警報を発する。
以上の例では、オペレータおよび軽油等の燃料の質量を標準的な一定値に設定し、上部旋回体3の質量に含める構成としたが、精度の高い安定判定が必要とされる場合や、機械自体の質量に対しオペレータによる体重差や燃料の残量の質量変化の占める割合が比較的大きい場合には、オペレータおよび燃料の質量に応じて上部旋回体3の質量および重心を変更するように構成しても良い。オペレータの質量については、運転席4内に体重計などを設置し、自動で計測するようにしても良いし、オペレータがユーザ設定入力装置55を用いて入力するようにしても良い。また、燃料の質量については燃料計により検出される燃料の残量に使用する燃料の比重をかけることによって算出する方法などが考えられる。
以上の例においては、オペレータは作業機械1上に備わる運転席4に搭乗し、作業機械1の操作を行うことを想定して説明した。一方、作業機械1の操作は無線等を用いた遠隔操作が行われるケースがある。遠隔操作時には、搭乗時に比べ作業機械の姿勢や路面の傾斜等を正確に把握するのが困難であり、また、熟練したオペレータでも作業機械の安定性を感覚的に把握することが困難である。したがって、遠隔操作時においては、オペレータに対する安定性情報の表示および警告は一層優れた効果を奏する。
以下に第1の実施形態におけるセンサの構成について、変更可能な例を示す(図1~図5参照)。
旋回角度には、地表面30に対する絶対方位を計測する方法と、下部走行体2に対する相対角度を計測する方法とがある。第1の実施形態では、相対角度を旋回角度センサ3sによって検出しているが、地磁気センサ、GPS等を用いて上部旋回体3および下部走行体2の絶対方位を検出し、絶対方位の差分によって相対的な旋回角を算出する構成としても良い。このような構成とすることによって旋回角度センサ3sの設置が困難な場合においても本発明を実施することが可能になる。
第1の実施形態では、作業フロント6の姿勢の検出にブーム角度センサ40a及びアーム角度センサ41aを用いているが、これら角度センサの変わりに傾斜角センサを用いる構成としてもよい。このような構成とすることによって、支点40および41に角度センサの設置が困難な場合においても本発明を実施することが可能になる。
第1の実施形態では、図3に示す各質点3P、10P、12Pの加速度を算出するのに上部旋回体加速度センサ3a、ブーム加速度センサ10a、アーム加速度センサ12aを用いているが、これら加速度センサを設けず、角度センサの値を二階微分して加速度を求めてもよい。例えば、上部旋回体3の回転加速度を求める場合、旋回角度センサ3sによって検出される上部旋回体3の回転角度を二階微分することで、上部旋回体3の回転加速度を求めてもよい。このような構成とする場合には、二階微分による計測ノイズの留意する必要があるが、設置するセンサの数を減ずることが可能であり、また、制御装置60に送信すべき信号が減少するため、より安価かつ簡易な構成とすることができる。
第1の実施形態では、姿勢センサ3bを上部旋回体3に設置しているが、下部走行体2に設置する構成としても良い。このような構成とすることによって、旋回角度センサ3sの検出値を用いずにワールド座標系に対する機械基準座標系の傾きを算出することができる。
第1の実施形態では、路面の傾斜の検出に上部旋回体3の姿勢センサ3bを用いているが、下部走行体加速度センサ2aとして、直流成分(重力)の計測が可能な加速度センサを用いる場合には、姿勢センサ3bを設けない構成としても良い。このような場合には、設置するセンサの数が減少し、また、制御装置60に送信すべき信号が減少するため、より安価かつ簡易な構成とすることができる。
例えば、定置ヤード内でのスクラップ処理作業のように、作業機械1が使われる現場が水平な現場に限られている場合、作業機械1の傾斜による各質点の位置ベクトルrや外力作用点位置ベクトルsの変化が十分に小さい。
<下部走行体加速度センサなし>
また、下部走行体2の加速度については、上部旋回体3の加速度と、旋回角度センサ3sが検出する旋回角度から推定する構成とし、下部走行体2の加速度を検出する下部走行体加速度センサ2aを設けない構成としてもよい。
ブレード接地判定手段60dにおいてブレードの接地の有無はオペレータがユーザ設定入力装置55を用いて入力する構成とし、ブレードシリンダ圧力センサ19i、19oを設けない構成としてもよい。
作業機械1が旋回動作を行わない場合、上部旋回体3の慣性力によって発生するモーメントは、作業フロント6の慣性力によって発生するモーメントと比較して非常に小さい。
作業機械1(図1参照)が旋回力を用いて作業を行わない場合、バケット23には横方向の外力がほとんど加わらない。そのため、作業中に外力によって安定性が悪化する恐れが無い、このような場合には、横方向の外力を計測するための、旋回モータ7の吸入側圧力および吐出側圧力を検出する旋回モータ圧力センサ7i及び7oを設けない構成としてもよい。このような場合には、設置するセンサの数が減少し、また、制御装置60に送信すべき信号が減少するため、より安価かつ簡易な構成となる。また、横方向外力の算出を行わないため、演算量を減ずることが可能である。
以上では、バケットに加わる外力の検出にピン力センサ43a、44aを設ける例を示したが、その他の検出方法としてブームシリンダに圧力センサ11a、11bを設ける方法がある。この方法では、ブームシリンダに設けた圧力センサ11a、11bの検出値からバケット外力と作業フロント自重とを含んだモーメントMlを算出し、また、ブーム、アーム、バケットの各角度センサの検出値とブーム、アーム、バケットの各重心パラメータとから作業フロントの自重モーメントMocを算出する。次いで前記モーメントMlとMocとの差分および旋回中心からバケットまでの距離からバケット外力を算出する。
例えば、作業機械1が作業具として、図示しないカッタを装備し、主に切断作業のみを行う場合、切断作業はカッタの内力を利用して行うため、作業中に作業フロント6には外力がほとんど加わらない。そこで、作業中に外力によって安定性が悪化する恐れが無い、このような場合には、ピン43、44(図1参照)に作用する外力を検出するピン力センサ43a、44aを設けない構成としてもよい。
<スイングポスト型>
次に、本発明の第2の実施形態を、図10および図11を参照して説明する。図10は、第2の実施形態における作業機械を示す概略側面図、図11は、第2の実施形態にかかる上部旋回体をモデル化して示す上面図である。図10および図11において、第1の実施形態と同等の構成要素については同じ符号を付し、説明は省略する。
<本体>
図10に示すように、第2の実施形態にかかる作業機械1aには、下部走行体2に上部旋回体3が旋回可能に取付けられ、上部旋回体3は旋回モータ7によって駆動される。その上部旋回体3に運転室4、カウンタウエイト8等が取付けられている。また、上部旋回体3の前方には支点45で左右揺動自在にスイングポスト24が設けられており、スイングポスト24は、上部旋回体3とスイングポスト24とに連結されたスイングシリンダ25(図11参照)によって左右揺動される。また、作業機械1aは、作業機械1a全体を制御する制御装置80を備える。
また、スイングポスト24には支点40で上下揺動自在にブーム10が設けられており、ブーム10には支点41で揺動自在にアーム12が設けられている。さらに、アーム12には支点42で回動自在にバケット23が設けられる。そして、第1の実施形態と同様にブーム10、アーム12で作業フロント6が構成される。
上部旋回体3には、作業機械1aを操作するオペレータ用の運転室4が備わり、運転室4の中には、第1の実施形態と同様に操作装置50、表示装置61、および警報装置63が設けられる。
作業機械1aには、第1の実施形態と同様に、旋回角度センサ3s、姿勢センサ3b、ブーム角度センサ40a、アーム角度センサ41a、バケット角度センサ42a、下部走行体加速度センサ2a、上部旋回体加速度センサ3a、ブーム加速度センサ10a、アーム加速度センサ12aが設けられている。
これらに加え、上部旋回体3とスイングポスト24の支点45には、スイングポスト24の回動角度を検出するためのスイング角度センサ45aが設けられている。
図11に示すように、スイングポストシリンダ25を駆動する油圧の吸入側および吐出側には、吸入側圧力および吐出側圧力を検出するスイング圧力センサ25iおよび25oが設けられている。
図12は、第2の実施形態に係る作業機械に備わる制御装置の概略構成図である。図10に示す制御装置80の機能ブロックのうち、第1の実施形態に係る制御装置60の機能ブロックと同等ものについては同じ符号を付し、説明は省略する。
バケット23(図10参照)に加わる横方向の外力は、直接計測することが困難であるので、スイングシリンダ25(図11参照)に設けたスイング圧力センサ25iおよび25oが検出する、スイングシリンダ25を駆動する油圧の吸入側圧力および吐出側圧力から算出する。より具体的には、図11に示すモデルを用いる。
図10に示すように、作業機械1aの各部に配された姿勢センサ3b、旋回角度センサ3s、スイング角度センサ45a、ブーム角度センサ40a、アーム角度センサ41a、バケット角度センサ42a、下部走行体加速度センサ2a、上部旋回体加速度センサ3a、ブーム加速度センサ10a、アーム加速度センサ12a、ピン力センサ43a、44aの値と、横方向外力ベクトルF46を用いて順次運動学計算を行うことにより、各質点位置ベクトルr2、r3、r10、r12、各質点加速度ベクトルr´´2、r´´3、r´´10、r´´12、各外力作用点位置ベクトルs43、s44、各外力ベクトルF43、F44、F46を、機械基準座標系(O-XYZ)を基準とした値に変換する。
第2の実施形態においても、安定性演算手段60cがリンク演算の結果を用い、第1の実施形態と同様にしてZMP座標を算出し、安定判別を行う。
<オフセット型>
本発明の第3の実施形態を、図13および図14を参照して説明する。図13は、第3の実施形態における作業機械を示す概略側面図、図14は、第3の実施形態にかかる上部旋回体をモデル化して示す上面図である。図13および図14において、第1の実施形態と同等の構成要素については同じ符号を付し、説明は省略する。
<本体>
図13に示すように、第3の実施形態にかかる作業機械1bは主に、下部走行体2、上部旋回体3、上部旋回体3を駆動する旋回モータ7によって構成される。上部旋回体3には運転室4、カウンタウエイト8等が設けられている。また、作業機械1b全体を制御する制御装置90を備える。
作業フロント6は、上部旋回体3に上下揺動自在に設けられたブーム(ロアブーム)10、ブーム10の先端側に設けられたアッパブーム26、アッパブーム26の先端側に設けられたアーム支持体28、アーム支持体28の先端側に揺動自在に取付けられたアーム12、アーム12の先端側に回動自在に取付けられたバケット23、ブーム10とアーム支持体28との間を連結するリンクロッド29、ブーム10を駆動させるブームシリンダ11、アーム12を駆動させるアームシリンダ13、バケット23を駆動させる作業具シリンダ15およびアッパブーム26を左右方向に揺動させるオフセットシリンダ27を備える。
また、上部旋回体3には、作業機械1bを操作するオペレータ用の運転室4が備わり、運転室4の中には、第1の実施形態と同様に操作装置50、表示装置61、および警報装置63とが設けられる。
図13に示すように、作業機械1bには、第1の実施形態と同様に、旋回角度センサ3s、姿勢センサ3b、ブーム角度センサ40a、アーム角度センサ41a、バケット角度センサ42a、下部走行体加速度センサ2a、上部旋回体加速度センサ3a、ブーム加速度センサ10a、アーム加速度センサ12aが設けられている。
前記の各センサに加え、図14に示すように、オフセットの支点48には、支点48における回転角度を検出するためのオフセット角度センサ48aが設けられている。
さらに、オフセットシリンダ27には、オフセットシリンダ27を駆動する油圧の吸入側圧力および吐出側圧力を検出するオフセット圧力センサ27iおよび27oが設けられている。
図15は、第3の実施形態に係る作業機械に備わる制御装置の概略構成図である。図15に示す制御装置90の機能ブロックのうち、第1の実施形態に係る制御装置60の機能ブロックと同等ものについては同じ符号を付し、説明は適宜省略する。
図14に示すバケット23に加わる横方向の外力は、直接計測することが困難であるので、オフセットシリンダ27を駆動する油圧の吸入側圧力および吐出側圧力から算出する。より具体的には、図14に示すモデルを用いる。
図13に示すように作業機械1bの各部に配された、姿勢センサ3b、旋回角度センサ3s、ブーム角度センサ40a、アーム角度センサ41a、バケット角度センサ42a、オフセット角度センサ48a、下部走行体加速度センサ2a、上部旋回体加速度センサ3a、ブーム加速度センサ10a、アーム加速度センサ12a、ピン力センサ43a、44aの各検出値と、横方向外力ベクトルF46を用いて順次運動学計算を行うことにより、各質点位置ベクトルr2、r3、r10、r12、各質点加速度ベクトルr´´2、r´´3、r´´10、r´´12、各外力作用点位置ベクトルs43、s44、各外力ベクトルF43、F44、F46を機械基準座標系(O-XYZ)を基準とした値に変換する。
そして、安定性演算手段60cは、リンク演算の結果を用い、第1の実施形態と同様にしてZMP座標を算出し、安定判別を行う。
本発明の第4の実施形態を図16および図17を参照して説明する。図16は、第4の実施形態における作業機械を示す概略側面図、図17は第4の実施形態における支持多角形の一例を示す図である。図16および図17において、第1の実施形態と同等の構成要素については同じ符号を付し、説明は省略する。
<本体>
図16に示すように、第4の実施形態にかかる作業機械1cは主に、下部走行体2、上部旋回体3、上部旋回体3、上部旋回体3を駆動する旋回モータ7によって構成される。上部旋回体3には運転席4、カウンタウエイト8等が設けられている。また、作業機械1c全体を制御する制御装置90を備える。
下部走行体2は車輪35、アウトリガ36、アウトリガシリンダ37およびそれらを支持するフレームや車軸等から構成される。アウトリガ36はアウトリガシリンダ37によって駆動される。
作業フロント6の構成は、第1の実施形態と同等である。また運転席4の中には、第1の実施形態と同様に操作装置50、表示装置61、および警報装置63とが設けられる。
図16に示すように作業機械1cには、第1の実施形態と同様に、旋回角度センサ3s、姿勢センサ3b、ブーム角度センサ40a、アーム角度センサ41a、バケット角度センサ42a、下部走行体加速度センサ2a、上部旋回体加速度センサ3a、ブーム加速度センサ10a、アーム加速度センサ12aが設けられている。
制御装置60の基本構成は図2に示す第1の実施形態と同様である。制御装置60の機能ブロックのうち、第1の実施形態と同等のものについては説明を省略する。
安定性演算手段60cは第1の実施形態と同様にZMP演算手段60bで算出されるZMP70の座標を基に安定性判別を行う。安定性演算手段60cは、作業機械1と地表面30とで形成される支持多角形Lを算出し、その支持多角形Lに対し、転倒の可能性の十分低い通常領域Jと、転倒の可能性のより高い転倒警告領域Nを設定し、ZMP70の座標が通常領域Jにある場合、表示装置61に対し、安定性に関する情報を出力する。そして、ZMP70の座標が転倒警告領域Nにある場合、安定性演算手段60cは表示部61と警報装置63に対し、安定性の情報と転倒警告とを出力する。
以上、本発明にかかる第1~第4の実施形態を説明したが、いずれの実施形態においても、作業機械の動作状態に対応して安定判別の条件を変更し、変更された安定判別の条件に基づいて、作業機械の安定性を判別することができる。すなわち、運転者は、作業機械の動作状態に対応して時々刻々の安定性を確認することができ、安全性の高い作業を行うことができるという優れた効果を奏する。
2 下部走行体
2a 下部走行体加速度センサ(下部走行体速度検出手段)
3 上部旋回体
3a 上部旋回体加速度センサ(上部旋回体速度検出手段)
3b 姿勢センサ
3c 旋回中心線
3s 旋回角度センサ
4 運転室
6 作業フロント
7 旋回モータ
7i、7o 旋回モータ圧力センサ
10 ブーム(作業フロント)
10a ブーム加速度センサ(加速度センサ、ブーム速度検出手段)
12 アーム(作業フロント)
12a アーム加速度センサ(加速度センサ、アーム速度検出手段)
13 アームシリンダ
15 作業具シリンダ
18 ブレード
19 ブレードシリンダ
19i、19o ブレードシリンダ圧力センサ
23 バケット(作業具)
30 地表面
32 スプロケット(起動輪)
33 アイドラ(遊動輪)
34 下部ローラ
35 車輪
36 アウトリガ
37 アウトリガシリンダ
40、41、42 支点
40a ブーム角度センサ(角度センサ)
41a アーム角度センサ(角度センサ)
42a バケット角度センサ
43、44 ピン
43a、44a ピン力センサ
46 横方向外力作用点
50 操作レバー
55 ユーザ設定入力装置
60、80、90 制御装置
60a リンク演算手段
60b ZMP演算手段
60c 安定性演算手段
60d ブレード接地判定手段
60e ジャッキアップ判定手段
60f 横方向外力演算手段
61 表示装置(表示手段)
63 警報装置(警報手段)
70 ZMP座標
L 支持多角形
J 通常領域
N 転倒警告領域
K 境界
2P、3P、10P、12P 質点(重心位置)
Claims (6)
- 走行体、該走行体上に取り付けた作業機械本体、該作業機械本体に対し、上下方向に揺動自在に取り付けた作業フロント、および該作業フロントの先端に取り付けた作業具を備えた作業機械において、
前記作業フロントを含む前記本体および走行体の各可動部の位置情報、加速度情報、外力情報をそれぞれ用いてZMPの座標を算出するZMP演算手段と、
前記作業機械の地面との複数の接地点が形成する支持多角形を算出し、前記算出されたZMP座標を基に安定判別を行い、前記ZMPが前記支持多角形の周縁の内側に形成した警告領域に含まれるとき転倒警告を発する安定性演算手段を備え、
前記ZMP演算手段および安定性演算手段は、前記ZMPおよび前記警告領域を含む支持多角形を演算して表示あるいは警報することを特徴とする作業機械。
- 請求項1記載の作業機械において、
前記作業機械の動作角度を検出する角度センサと、前記作業機械の動作加速度を検出する加速度センサと、前記作業フロントと前記作業具とを連結するピンに加わる外力を検出するピン力センサとのうち少なくともいずれかを有し、
前記ZMP演算手段は前記センサの出力値に基づいて前記作業フロントを含む前記本体および走行体を構成する各可動部の位置ベクトル、加速度ベクトル、並びに外力ベクトルを算出することを特徴とする作業機械。
- 請求項1記載の作業機械において、
前記安定性演算手段は、前記支持多角形、前記警告領域および安定度を、作業状態やオペレータの指示に応じて逐次変更することを特徴とする作業機械。
- 請求項3記載の作業機械において、
前記走行体には、上下揺動自在に連結されるブレードと、
前記ブレードを駆動するブレードシリンダと、
前記ブレードシリンダを駆動する油圧の吸入側圧力および吐出側圧力を検出するブレードシリンダ圧力センサと、
前記ブレードシリンダ圧力センサの吸入側圧力と吐出側圧力の圧力差により、前記ブレードの接地状態を判定するブレード接地判定手段とを備え、
前記安定性演算手段は、前記ブレードが接地したことを前記ブレード接地判定手段が判定したときに、前記支持多角形の形状を変更することを特徴とする作業機械。
- 請求項3記載の作業機械において、
作業フロントに作業具を取り付けるピンに加わる外力を検出するピン力センサが検出した前記ピンに加わる外力と、前記走行体の傾斜角を検出する姿勢センサによって得られる前記走行体の傾斜角に基づいて、作業フロントによるジャッキアップの有無を判定するジャッキアップ判定手段を備え、
前記安定性判別手段は、前記ジャッキアップ判定手段がジャッキアップ状態と判定した場合には、前記支持多角形の形状を変更することを特徴とする作業機械。
- 請求項3記載の作業機械において、
前記走行体に対して上下揺動自在に取り付けたブーム、該ブームに関節を介して揺動自在に連結されたアームと、
前記ブームの動作速度を検出するブーム速度検出手段およびアームの動作速度を検出するアーム速度検出手段と、
前記下部走行体の走行速度を検出する下部走行体速度検出手段を有し、
前記安定性演算手段は、あらかじめ与えられた前記下部走行体の質量、前記ブームの質量、前記アームの質量、前記走行体速度検出手段が検出する前記走行体の走行速度、前記ブーム速度検出手段が検出する前記ブームの動作速度、及び前記アーム速度検出手段が検出する前記アームの動作速度に基づいて前記警告領域の大きさを変更することを特徴とする作業機械。
Priority Applications (5)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| US13/502,598 US8768580B2 (en) | 2009-10-19 | 2010-10-19 | Operation machine |
| EP10824928.5A EP2492404A4 (en) | 2009-10-19 | 2010-10-19 | OPERATING MACHINE |
| JP2011537258A JP5491516B2 (ja) | 2009-10-19 | 2010-10-19 | 作業機械 |
| KR1020127009975A KR101755739B1 (ko) | 2009-10-19 | 2010-10-19 | 작업 기계 |
| CN201080047042.0A CN102575457B (zh) | 2009-10-19 | 2010-10-19 | 作业机械 |
Applications Claiming Priority (2)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| JP2009-240511 | 2009-10-19 | ||
| JP2009240511 | 2009-10-19 |
Publications (1)
| Publication Number | Publication Date |
|---|---|
| WO2011049079A1 true WO2011049079A1 (ja) | 2011-04-28 |
Family
ID=43900303
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| PCT/JP2010/068356 Ceased WO2011049079A1 (ja) | 2009-10-19 | 2010-10-19 | 作業機械 |
Country Status (6)
| Country | Link |
|---|---|
| US (1) | US8768580B2 (ja) |
| EP (1) | EP2492404A4 (ja) |
| JP (1) | JP5491516B2 (ja) |
| KR (1) | KR101755739B1 (ja) |
| CN (1) | CN102575457B (ja) |
| WO (1) | WO2011049079A1 (ja) |
Cited By (16)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN103597147A (zh) * | 2011-06-10 | 2014-02-19 | 日立建机株式会社 | 作业机械 |
| JP5851037B2 (ja) * | 2012-07-20 | 2016-02-03 | 日立建機株式会社 | 作業機械 |
| JP2016183534A (ja) * | 2015-03-26 | 2016-10-20 | 住友建機株式会社 | 建設機械 |
| JP2017008659A (ja) * | 2015-06-25 | 2017-01-12 | Kyb株式会社 | Zmp演算装置およびzmp演算方法 |
| WO2017104238A1 (ja) * | 2015-12-18 | 2017-06-22 | 住友重機械工業株式会社 | ショベルおよびその制御方法 |
| JP2018192891A (ja) * | 2017-05-16 | 2018-12-06 | 株式会社クボタ | 作業機の状態管理システム |
| JP2019002242A (ja) * | 2017-06-19 | 2019-01-10 | 株式会社神戸製鋼所 | 転倒防止装置及び作業機械 |
| WO2019151335A1 (ja) * | 2018-01-30 | 2019-08-08 | 住友建機株式会社 | ショベル及びショベルの管理システム |
| JP2019190089A (ja) * | 2018-04-23 | 2019-10-31 | 日立建機株式会社 | 作業機械 |
| CN110395229A (zh) * | 2019-07-29 | 2019-11-01 | 北京航天发射技术研究所 | 一种基于远程无线控制的调平支撑装置和调平方法 |
| WO2020049623A1 (ja) * | 2018-09-03 | 2020-03-12 | 日立建機株式会社 | 作業機械 |
| JP2020159027A (ja) * | 2019-03-26 | 2020-10-01 | 日立建機株式会社 | 作業機械 |
| JPWO2019049490A1 (ja) * | 2017-09-07 | 2020-10-15 | 住友建機株式会社 | ショベル |
| WO2022190881A1 (ja) * | 2021-03-08 | 2022-09-15 | 株式会社小松製作所 | 転倒評価システム、転倒評価方法及び作業機械 |
| WO2022224624A1 (ja) * | 2021-04-19 | 2022-10-27 | 日立建機株式会社 | 作業機械 |
| WO2023084996A1 (ja) * | 2021-11-09 | 2023-05-19 | コベルコ建機株式会社 | 管理システム |
Families Citing this family (49)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| US8768581B2 (en) * | 2010-05-24 | 2014-07-01 | Hitachi Construction Machinery Co., Ltd. | Work machine safety device |
| GB2485770A (en) * | 2010-11-23 | 2012-05-30 | Flintec Uk Ltd | Lifting Device with Distributed-Sensing Scale |
| US20120283746A1 (en) * | 2011-05-02 | 2012-11-08 | Hstar Technologies | Mobile Medical Robotic System |
| GB2493946B (en) * | 2011-08-24 | 2017-07-19 | Fraser Dunphy James | Crane monitoring system |
| CN103857851B (zh) * | 2011-10-19 | 2016-03-09 | 住友重机械工业株式会社 | 回转作业机械及回转作业机械的控制方法 |
| USD686642S1 (en) * | 2012-05-10 | 2013-07-23 | Hitachi Construction Machinery Co., Ltd. | Swing post for a construction machine |
| JP6111562B2 (ja) * | 2012-08-31 | 2017-04-12 | セイコーエプソン株式会社 | ロボット |
| US8909437B2 (en) * | 2012-10-17 | 2014-12-09 | Caterpillar Inc. | Payload Estimation system |
| JP5969379B2 (ja) * | 2012-12-21 | 2016-08-17 | 住友建機株式会社 | ショベル及びショベル制御方法 |
| CN103255786A (zh) * | 2013-04-09 | 2013-08-21 | 常熟建工建设集团有限公司苏州分公司 | 一种新型单斗液压挖掘机的工作装置 |
| US9115581B2 (en) | 2013-07-09 | 2015-08-25 | Harnischfeger Technologies, Inc. | System and method of vector drive control for a mining machine |
| KR101531872B1 (ko) * | 2013-10-10 | 2015-06-26 | 재단법인대구경북과학기술원 | 이동장치의 배토판에 가해지는 외부 모멘트의 산출방법 |
| DE102013221302A1 (de) * | 2013-10-21 | 2015-04-23 | Mts Maschinentechnik Schrode Ag | Baumaschine |
| ES2537895B1 (es) * | 2013-11-14 | 2016-05-17 | Empresa De Transf Agraria S A (Tragsa) | Sistema y metodo para control de estabilidad en maquinaria pesada |
| KR101459028B1 (ko) * | 2014-04-25 | 2014-11-07 | 이호 | 아웃트리거를 장착한 크레인의 전도 방지 장치 |
| US9598845B2 (en) * | 2014-06-04 | 2017-03-21 | Komatsu Ltd. | Posture computing apparatus for work machine, work machine, and posture computation method for work machine |
| CN106536944B (zh) * | 2014-06-18 | 2019-04-16 | 凯斯纽荷兰(中国)管理有限公司 | 安全液压回路 |
| EP3020868B1 (en) * | 2014-11-14 | 2020-11-04 | Caterpillar Inc. | Machine of a kind comprising a body and an implement movable relative to the body with a system for assisting a user of the machine |
| EP3021178B1 (en) * | 2014-11-14 | 2020-02-19 | Caterpillar Inc. | System using radar apparatus for assisting a user of a machine of a kind comprising a body and an implement |
| US10120369B2 (en) | 2015-01-06 | 2018-11-06 | Joy Global Surface Mining Inc | Controlling a digging attachment along a path or trajectory |
| DE102015102368A1 (de) * | 2015-02-19 | 2016-08-25 | Schwing Gmbh | Positionsregelung Mastspitze |
| US10048158B2 (en) * | 2015-09-30 | 2018-08-14 | Deere & Company | Stability warning and control intervention system for a forestry vehicle |
| JP6306552B2 (ja) * | 2015-10-13 | 2018-04-04 | 株式会社タダノ | 遠隔操作装置、及び案内システム |
| DE102016000353A1 (de) * | 2016-01-14 | 2017-07-20 | Liebherr-Components Biberach Gmbh | Kran-, Baumaschinen- oder Flurförderzeug-Simulator |
| WO2017170555A1 (ja) * | 2016-03-31 | 2017-10-05 | 住友重機械工業株式会社 | ショベル |
| JP7571963B2 (ja) * | 2016-09-30 | 2024-10-23 | 住友建機株式会社 | ショベル |
| CN106829813A (zh) * | 2017-01-19 | 2017-06-13 | 徐工消防安全装备有限公司 | 一种臂架式高空作业车行走动平衡控制装置及方法 |
| CN110114244B (zh) * | 2017-02-17 | 2023-07-04 | 住友重机械工业株式会社 | 工作机械用周边监视系统 |
| KR102137469B1 (ko) * | 2017-03-29 | 2020-07-24 | 히다찌 겐끼 가부시키가이샤 | 작업 기계 |
| JP6918654B2 (ja) * | 2017-09-11 | 2021-08-11 | 日立建機株式会社 | 作業車両 |
| JP6824856B2 (ja) * | 2017-09-29 | 2021-02-03 | 株式会社小松製作所 | 表示制御装置および表示制御方法 |
| KR20200105651A (ko) * | 2018-01-10 | 2020-09-08 | 스미토모 겐키 가부시키가이샤 | 쇼벨 및 쇼벨의 관리시스템 |
| CN108411974A (zh) * | 2018-02-01 | 2018-08-17 | 三峡大学 | 一种挖掘机安全装载量自动防倾覆报警系统 |
| GB2573304A (en) * | 2018-05-01 | 2019-11-06 | Caterpillar Inc | A method of operating a machine comprising am implement |
| WO2019244574A1 (ja) * | 2018-06-19 | 2019-12-26 | 住友建機株式会社 | 掘削機、情報処理装置 |
| US10767348B2 (en) * | 2018-07-30 | 2020-09-08 | Deere & Company | Machine stability detection and control |
| JP7265323B2 (ja) * | 2018-07-31 | 2023-04-26 | 株式会社小松製作所 | 作業機械を制御するためのシステム及び方法 |
| JP7024139B2 (ja) * | 2019-03-29 | 2022-02-22 | 日立建機株式会社 | 作業機械 |
| KR102077493B1 (ko) * | 2019-06-13 | 2020-04-08 | 재단법인 한국전자기계융합기술원 | 굴삭기 전복 감지 시스템 |
| JP7264796B2 (ja) * | 2019-11-21 | 2023-04-25 | 株式会社小松製作所 | 転倒リスク提示装置および転倒リスク提示方法 |
| CN110908318B (zh) * | 2019-12-17 | 2020-10-13 | 三一重机有限公司 | 一种挖掘机倾倒的控制方法、控制装置及可读存储介质 |
| CN111042261A (zh) * | 2019-12-30 | 2020-04-21 | 三一重机有限公司 | 挖掘机动态称重方法及系统 |
| US11421402B2 (en) * | 2020-02-05 | 2022-08-23 | Caterpillar Paving Products Inc. | Operation-based object detection for a work machine |
| US11918535B2 (en) * | 2020-04-13 | 2024-03-05 | Toyota Research Institute, Inc. | Wearable exoskeleton |
| KR20220030098A (ko) * | 2020-09-02 | 2022-03-10 | 현대두산인프라코어(주) | 자율 작업 굴착기 및 그의 동작 방법 |
| CN112499533A (zh) * | 2020-10-30 | 2021-03-16 | 徐州海伦哲特种车辆有限公司 | 一种臂架类作业车动态幅度限制方法 |
| US12385224B2 (en) * | 2022-03-31 | 2025-08-12 | Hitachi Construction Machinery Co., Ltd. | Wheeled construction machine |
| CN116220127A (zh) * | 2023-02-22 | 2023-06-06 | 长沙仁毅机械制造有限公司 | 一种高空移动式挖机 |
| EP4715129A1 (en) * | 2024-09-24 | 2026-03-25 | Volvo Truck Corporation | Tip-over mitigation for vehicles |
Citations (5)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JPH05319785A (ja) | 1991-09-06 | 1993-12-03 | Yotaro Hatamura | 建設機械の姿勢制御システム |
| JPH07180192A (ja) | 1993-12-24 | 1995-07-18 | Hitachi Constr Mach Co Ltd | 油圧シヨベルの転倒防止装置 |
| JP2871105B2 (ja) | 1990-12-03 | 1999-03-17 | 油谷重工株式会社 | 解体作業機の安全装置 |
| JP2006150567A (ja) * | 2004-12-01 | 2006-06-15 | Toyota Motor Corp | ロボットの安定化制御装置 |
| JP2008012642A (ja) * | 2006-07-07 | 2008-01-24 | Fujitsu Ltd | 移動型ロボット |
Family Cites Families (12)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| US4284987A (en) * | 1979-09-07 | 1981-08-18 | The United States Of America As Represented By The Secretary Of Agriculture | Slope stability warning device for articulated tractors |
| GB8612424D0 (en) * | 1986-05-22 | 1986-07-02 | Arcubos Systems Ltd | Weight sensing device |
| US5160055A (en) * | 1991-10-02 | 1992-11-03 | Jlg Industries, Inc. | Load moment indicator system |
| JP3194611B2 (ja) * | 1992-01-29 | 2001-07-30 | 株式会社小松製作所 | 油圧ショベルの転倒防止装置 |
| JPH09105155A (ja) * | 1995-10-11 | 1997-04-22 | Hitachi Constr Mach Co Ltd | 建設機械の姿勢安定度算出装置 |
| US6991119B2 (en) * | 2002-03-18 | 2006-01-31 | Jlg Industries, Inc. | Measurement system and method for assessing lift vehicle stability |
| GB2412902B (en) * | 2004-04-07 | 2008-04-09 | Linde Ag | Industrial truck having increased static or quasi-static tipping stability |
| JP4142692B2 (ja) * | 2006-02-07 | 2008-09-03 | 株式会社竹内製作所 | 作業車のバッテリ配置構造 |
| US7870919B2 (en) * | 2007-02-28 | 2011-01-18 | Crown Equipment Corporation | Materials handling vehicle |
| US8086370B2 (en) * | 2007-10-05 | 2011-12-27 | Nacco | Load controlled stabilizer system |
| CN201158831Y (zh) * | 2008-02-26 | 2008-12-03 | 山东交通学院 | 一种道路与铁路两栖挖掘机 |
| GB2471134B (en) * | 2009-06-19 | 2012-10-10 | Bamford Excavators Ltd | Speed sensitive longitudinal load moment control of a working machine |
-
2010
- 2010-10-19 US US13/502,598 patent/US8768580B2/en active Active
- 2010-10-19 JP JP2011537258A patent/JP5491516B2/ja active Active
- 2010-10-19 CN CN201080047042.0A patent/CN102575457B/zh not_active Expired - Fee Related
- 2010-10-19 EP EP10824928.5A patent/EP2492404A4/en not_active Withdrawn
- 2010-10-19 KR KR1020127009975A patent/KR101755739B1/ko not_active Expired - Fee Related
- 2010-10-19 WO PCT/JP2010/068356 patent/WO2011049079A1/ja not_active Ceased
Patent Citations (5)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JP2871105B2 (ja) | 1990-12-03 | 1999-03-17 | 油谷重工株式会社 | 解体作業機の安全装置 |
| JPH05319785A (ja) | 1991-09-06 | 1993-12-03 | Yotaro Hatamura | 建設機械の姿勢制御システム |
| JPH07180192A (ja) | 1993-12-24 | 1995-07-18 | Hitachi Constr Mach Co Ltd | 油圧シヨベルの転倒防止装置 |
| JP2006150567A (ja) * | 2004-12-01 | 2006-06-15 | Toyota Motor Corp | ロボットの安定化制御装置 |
| JP2008012642A (ja) * | 2006-07-07 | 2008-01-24 | Fujitsu Ltd | 移動型ロボット |
Non-Patent Citations (2)
| Title |
|---|
| See also references of EP2492404A4 |
| YOSHIKAWA, TSUNEO: "Robotto Seigyo Kisoron", 1988, CORONA PUBLISHING CO., LTD. |
Cited By (34)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN103597147B (zh) * | 2011-06-10 | 2016-05-25 | 日立建机株式会社 | 作业机械 |
| CN103597147A (zh) * | 2011-06-10 | 2014-02-19 | 日立建机株式会社 | 作业机械 |
| JP5851037B2 (ja) * | 2012-07-20 | 2016-02-03 | 日立建機株式会社 | 作業機械 |
| JP2016183534A (ja) * | 2015-03-26 | 2016-10-20 | 住友建機株式会社 | 建設機械 |
| JP2017008659A (ja) * | 2015-06-25 | 2017-01-12 | Kyb株式会社 | Zmp演算装置およびzmp演算方法 |
| KR102565925B1 (ko) | 2015-12-18 | 2023-08-09 | 스미도모쥬기가이고교 가부시키가이샤 | 쇼벨 및 그 제어방법 |
| WO2017104238A1 (ja) * | 2015-12-18 | 2017-06-22 | 住友重機械工業株式会社 | ショベルおよびその制御方法 |
| KR20180096595A (ko) * | 2015-12-18 | 2018-08-29 | 스미도모쥬기가이고교 가부시키가이샤 | 쇼벨 및 그 제어방법 |
| JPWO2017104238A1 (ja) * | 2015-12-18 | 2018-10-04 | 住友重機械工業株式会社 | ショベルおよびその制御方法 |
| JP7084722B2 (ja) | 2015-12-18 | 2022-06-15 | 住友重機械工業株式会社 | ショベルおよびその制御方法 |
| JP2018192891A (ja) * | 2017-05-16 | 2018-12-06 | 株式会社クボタ | 作業機の状態管理システム |
| JP2019002242A (ja) * | 2017-06-19 | 2019-01-10 | 株式会社神戸製鋼所 | 転倒防止装置及び作業機械 |
| JP7289787B2 (ja) | 2017-09-07 | 2023-06-12 | 住友建機株式会社 | ショベル |
| JPWO2019049490A1 (ja) * | 2017-09-07 | 2020-10-15 | 住友建機株式会社 | ショベル |
| WO2019151335A1 (ja) * | 2018-01-30 | 2019-08-08 | 住友建機株式会社 | ショベル及びショベルの管理システム |
| JPWO2019151335A1 (ja) * | 2018-01-30 | 2021-01-14 | 住友建機株式会社 | ショベル及びショベルの管理システム |
| JP2019190089A (ja) * | 2018-04-23 | 2019-10-31 | 日立建機株式会社 | 作業機械 |
| WO2020049623A1 (ja) * | 2018-09-03 | 2020-03-12 | 日立建機株式会社 | 作業機械 |
| JPWO2020049623A1 (ja) * | 2018-09-03 | 2020-09-10 | 日立建機株式会社 | 作業機械 |
| US11352761B2 (en) | 2018-09-03 | 2022-06-07 | Hitachi Construction Machinery Co., Ltd. | Work machine with jacked-up state control |
| WO2020194914A1 (ja) * | 2019-03-26 | 2020-10-01 | 日立建機株式会社 | 作業機械 |
| US12012723B2 (en) | 2019-03-26 | 2024-06-18 | Hitachi Construction Machinery Co., Ltd. | Work machine |
| JP2020159027A (ja) * | 2019-03-26 | 2020-10-01 | 日立建機株式会社 | 作業機械 |
| JP7222775B2 (ja) | 2019-03-26 | 2023-02-15 | 日立建機株式会社 | 作業機械 |
| CN110395229A (zh) * | 2019-07-29 | 2019-11-01 | 北京航天发射技术研究所 | 一种基于远程无线控制的调平支撑装置和调平方法 |
| JP2022136513A (ja) * | 2021-03-08 | 2022-09-21 | 株式会社小松製作所 | 転倒評価システム、転倒評価方法及び作業機械 |
| WO2022190881A1 (ja) * | 2021-03-08 | 2022-09-15 | 株式会社小松製作所 | 転倒評価システム、転倒評価方法及び作業機械 |
| JP7706901B2 (ja) | 2021-03-08 | 2025-07-14 | 株式会社小松製作所 | 転倒評価システム、転倒評価方法及び作業機械 |
| US12480283B2 (en) | 2021-03-08 | 2025-11-25 | Komatsu Ltd. | Fall evaluation system, fall evaluation method, and work machine |
| JPWO2022224624A1 (ja) * | 2021-04-19 | 2022-10-27 | ||
| WO2022224624A1 (ja) * | 2021-04-19 | 2022-10-27 | 日立建機株式会社 | 作業機械 |
| JP7375260B2 (ja) | 2021-04-19 | 2023-11-07 | 日立建機株式会社 | 作業機械 |
| WO2023084996A1 (ja) * | 2021-11-09 | 2023-05-19 | コベルコ建機株式会社 | 管理システム |
| US12612766B2 (en) | 2021-11-09 | 2026-04-28 | Kobelco Construction Machinery Co., Ltd. | Management system |
Also Published As
| Publication number | Publication date |
|---|---|
| JP5491516B2 (ja) | 2014-05-14 |
| EP2492404A1 (en) | 2012-08-29 |
| EP2492404A4 (en) | 2015-12-09 |
| US8768580B2 (en) | 2014-07-01 |
| KR101755739B1 (ko) | 2017-07-19 |
| US20120232763A1 (en) | 2012-09-13 |
| KR20120095875A (ko) | 2012-08-29 |
| JPWO2011049079A1 (ja) | 2013-03-14 |
| CN102575457B (zh) | 2014-12-17 |
| CN102575457A (zh) | 2012-07-11 |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| JP5491516B2 (ja) | 作業機械 | |
| CN102906347B (zh) | 作业机械的安全装置 | |
| JP6023053B2 (ja) | 作業機械 | |
| KR102126772B1 (ko) | 작업 기계 | |
| CN103046606B (zh) | 工程机械设备、可移动式配重系统及控制方法 | |
| US9745727B2 (en) | System and method for controlling stability in heavy machinery | |
| JP2019052499A (ja) | 作業機械 | |
| JP6814763B2 (ja) | 作業機械 | |
| JPWO2019186840A1 (ja) | 作業機械 | |
| JP6877385B2 (ja) | 作業機械 | |
| CN115383758B (zh) | 一种工程作业机器人防倾覆预警方法 | |
| JP2021147772A (ja) | 作業機械及び作業機械の疲労検出方法 | |
| CN119038425A (zh) | 汽车起重机的倾覆预警系统与抗倾覆方法 | |
| EP4026956B1 (en) | Work machine, measurement method, and system | |
| KR101776819B1 (ko) | 굴삭기 전도 상태 판별 방법 | |
| WO2022224624A1 (ja) | 作業機械 | |
| JPH07247578A (ja) | 解体作業機の安全装置 | |
| US12480283B2 (en) | Fall evaluation system, fall evaluation method, and work machine | |
| JP2024106742A (ja) | 旋回作業車 | |
| JP2023088479A (ja) | 転倒評価システム、転倒評価方法及び作業機械 | |
| JP2017008659A (ja) | Zmp演算装置およびzmp演算方法 |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| WWE | Wipo information: entry into national phase |
Ref document number: 201080047042.0 Country of ref document: CN |
|
| 121 | Ep: the epo has been informed by wipo that ep was designated in this application |
Ref document number: 10824928 Country of ref document: EP Kind code of ref document: A1 |
|
| WWE | Wipo information: entry into national phase |
Ref document number: 2010824928 Country of ref document: EP |
|
| ENP | Entry into the national phase |
Ref document number: 20127009975 Country of ref document: KR Kind code of ref document: A |
|
| WWE | Wipo information: entry into national phase |
Ref document number: 2011537258 Country of ref document: JP |
|
| WWE | Wipo information: entry into national phase |
Ref document number: 13502598 Country of ref document: US |