WO2019083021A1 - エンジンシステム - Google Patents
エンジンシステムInfo
- Publication number
- WO2019083021A1 WO2019083021A1 PCT/JP2018/039935 JP2018039935W WO2019083021A1 WO 2019083021 A1 WO2019083021 A1 WO 2019083021A1 JP 2018039935 W JP2018039935 W JP 2018039935W WO 2019083021 A1 WO2019083021 A1 WO 2019083021A1
- Authority
- WO
- WIPO (PCT)
- Prior art keywords
- piston
- engine system
- cylinder
- detection
- cylinder liner
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Ceased
Links
Images


Classifications
-
- F—MECHANICAL ENGINEERING; LIGHTING; HEATING; WEAPONS; BLASTING
- F02—COMBUSTION ENGINES; HOT-GAS OR COMBUSTION-PRODUCT ENGINE PLANTS
- F02B—INTERNAL-COMBUSTION PISTON ENGINES; COMBUSTION ENGINES IN GENERAL
- F02B75/00—Other engines
- F02B75/04—Engines with variable distances between pistons at top dead-centre positions and cylinder heads
-
- F—MECHANICAL ENGINEERING; LIGHTING; HEATING; WEAPONS; BLASTING
- F02—COMBUSTION ENGINES; HOT-GAS OR COMBUSTION-PRODUCT ENGINE PLANTS
- F02B—INTERNAL-COMBUSTION PISTON ENGINES; COMBUSTION ENGINES IN GENERAL
- F02B25/00—Engines characterised by using fresh charge for scavenging cylinders
- F02B25/02—Engines characterised by using fresh charge for scavenging cylinders using unidirectional scavenging
- F02B25/04—Engines having ports both in cylinder head and in cylinder wall near bottom of piston stroke
-
- F—MECHANICAL ENGINEERING; LIGHTING; HEATING; WEAPONS; BLASTING
- F02—COMBUSTION ENGINES; HOT-GAS OR COMBUSTION-PRODUCT ENGINE PLANTS
- F02B—INTERNAL-COMBUSTION PISTON ENGINES; COMBUSTION ENGINES IN GENERAL
- F02B75/00—Other engines
- F02B75/04—Engines with variable distances between pistons at top dead-centre positions and cylinder heads
- F02B75/045—Engines with variable distances between pistons at top dead-centre positions and cylinder heads by means of a variable connecting rod length
-
- F—MECHANICAL ENGINEERING; LIGHTING; HEATING; WEAPONS; BLASTING
- F02—COMBUSTION ENGINES; HOT-GAS OR COMBUSTION-PRODUCT ENGINE PLANTS
- F02D—CONTROLLING COMBUSTION ENGINES
- F02D15/00—Varying compression ratio
- F02D15/02—Varying compression ratio by alteration or displacement of piston stroke
-
- F—MECHANICAL ENGINEERING; LIGHTING; HEATING; WEAPONS; BLASTING
- F16—ENGINEERING ELEMENTS AND UNITS; GENERAL MEASURES FOR PRODUCING AND MAINTAINING EFFECTIVE FUNCTIONING OF MACHINES OR INSTALLATIONS; THERMAL INSULATION IN GENERAL
- F16J—PISTONS; CYLINDERS; SEALINGS
- F16J1/00—Pistons; Trunk pistons; Plungers
- F16J1/02—Bearing surfaces
-
- F—MECHANICAL ENGINEERING; LIGHTING; HEATING; WEAPONS; BLASTING
- F02—COMBUSTION ENGINES; HOT-GAS OR COMBUSTION-PRODUCT ENGINE PLANTS
- F02B—INTERNAL-COMBUSTION PISTON ENGINES; COMBUSTION ENGINES IN GENERAL
- F02B75/00—Other engines
- F02B75/32—Engines characterised by connections between pistons and main shafts and not specific to preceding main groups
-
- Y—GENERAL TAGGING OF NEW TECHNOLOGICAL DEVELOPMENTS; GENERAL TAGGING OF CROSS-SECTIONAL TECHNOLOGIES SPANNING OVER SEVERAL SECTIONS OF THE IPC; TECHNICAL SUBJECTS COVERED BY FORMER USPC CROSS-REFERENCE ART COLLECTIONS [XRACs] AND DIGESTS
- Y02—TECHNOLOGIES OR APPLICATIONS FOR MITIGATION OR ADAPTATION AGAINST CLIMATE CHANGE
- Y02T—CLIMATE CHANGE MITIGATION TECHNOLOGIES RELATED TO TRANSPORTATION
- Y02T10/00—Road transport of goods or passengers
- Y02T10/10—Internal combustion engine [ICE] based vehicles
- Y02T10/12—Improving ICE efficiencies
Definitions
- Patent Document 1 discloses a large reciprocating piston combustion engine having a crosshead.
- the large-sized reciprocating piston combustion engine of Patent Document 1 is a dual fuel engine that can be operated with both liquid fuel such as heavy oil and gaseous fuel such as natural gas.
- the large reciprocating piston combustion engine of Patent Document 1 changes the compression ratio by moving the piston rod by hydraulic pressure to correspond to both the compression ratio suitable for operation with liquid fuel and the compression ratio suitable for operation with gaseous fuel.
- An adjustment mechanism is provided at the crosshead portion.
- An engine system having a compression adjustment device that changes the compression ratio as described above changes the bottom dead center position and the top dead center position of the piston by changing the position in the movement direction of the piston rod, and adjusts the compression ratio doing.
- Such adjustment of the compression ratio is performed by the control system of the engine system based on the operation of the operator or the like.
- the control device does not know the position of the piston rod, and it may be difficult to accurately adjust the compression ratio.
- the present disclosure has been made in view of the above-described problems, and it is an object of the present disclosure to accurately obtain a compression ratio in an engine system having a variable compression device.
- An engine system is a variable compression device having a fluid chamber in which a piston rod connected to a piston is moved in a direction to increase a compression ratio by being supplied with a boosted working fluid. It has a detection device which outputs a signal including position information of the above-mentioned piston, and a position acquisition device which acquires the position of the above-mentioned piston based on the above-mentioned signal.
- the detection device is at least partially provided on a cylinder liner in which the piston slides therein, and detects the position of the piston in the sliding direction It is configured to
- the detection device includes a detection target provided on the piston and a detection part provided on the cylinder liner.
- a plurality of the detection target portions are provided in the circumferential direction on the sliding surface of the piston.
- the detection portion is provided at a position farther from the combustion chamber than the scavenging port of the cylinder liner in the sliding direction of the piston.
- the detection device outputs a signal including positional information in the movement direction (sliding direction) of the piston
- the position acquisition device acquires the positional information of the piston and the control provided in the engine system.
- the unit controls a pressure increasing mechanism that adjusts the pressure in the fluid chamber based on the position information.
- the control unit can obtain an accurate position in the movement direction of the piston and constantly monitor whether it matches the position of the target piston.
- the control unit can control the variable compression device more stably by accurately grasping the position of the piston.
- FIG. 1 is a cross-sectional view of an engine system in accordance with an embodiment of the present disclosure. It is a schematic cross section which shows a part of engine system in one embodiment of this indication. 1 is an enlarged schematic cross-sectional view showing a part of an engine system according to an embodiment of the present disclosure.
- the engine system 100 of the present embodiment is mounted on a ship such as a large tanker, for example, and as shown in FIG. 1, the engine 1, the supercharger 200, the control unit 300 (position acquisition device), and the position detection unit 400 ( Detection device).
- the turbocharger 200 will be described as an accessory and will be described separately from the engine 1 (main engine).
- the supercharger 200 is not an essential component of the engine system 100 according to the present embodiment, and may not be provided in the engine system 100.
- FIG. 1 is a longitudinal cross-sectional view along a central axis of a cylindrical cylinder liner 3a provided in an engine system 100, which will be described later.
- the side on which the exhaust valve unit 5 described later is provided may be referred to as the upper side, and the side on which the crankshaft 11 described later is provided may be referred to as the lower side.
- the view from the center axis direction of the cylinder liner 3a may be referred to as a plan view.
- the engine 1 is a multi-cylinder uniflow scavenging diesel engine, and can execute a gas operation mode in which a gaseous fuel such as natural gas is burned together with a liquid fuel such as heavy oil, and a diesel operation mode in which a liquid fuel such as heavy oil is burned It is a dual fuel engine. In the gas operation mode, only gaseous fuel may be burned.
- Such an engine 1 includes a frame 2, a cylinder portion 3, a piston 4, an exhaust valve unit 5, a piston rod 6, a cross head 7, a hydraulic portion 8 (boost mechanism), and a connecting rod 9.
- a crank angle sensor 10, a crankshaft 11, a scavenging air reservoir 12, an exhaust reservoir 13 and an air cooler 14 are provided. Further, a cylinder is constituted by the cylinder portion 3, the piston 4, the exhaust valve unit 5 and the piston rod 6.
- the frame 2 is a strength member that supports the entire engine 1, and the crosshead 7, the hydraulic unit 8, and the connecting rod 9 are accommodated.
- a cross head pin 7a, which will be described later, of the cross head 7 can reciprocate.
- the cylinder portion 3 has a cylindrical cylinder liner 3a, a cylinder head 3b and a cylinder jacket 3c.
- the cylinder liner 3a is a cylindrical member, and the sliding surface with the piston 4 is formed on the inner side (inner peripheral surface).
- a space surrounded by the inner circumferential surface of the cylinder liner 3a and the piston 4 is a combustion chamber R1.
- a plurality of scavenging ports S are formed in the lower portion of the cylinder liner 3a.
- the scavenging port S is an opening arranged along the circumferential surface of the cylinder liner 3a, and communicates the scavenging chamber R2 inside the cylinder jacket 3c with the inside of the cylinder liner 3a.
- the cylinder head 3 b is a lid member provided at the upper end portion of the cylinder liner 3 a.
- the cylinder head 3 b is formed with an exhaust port H at a central portion in plan view, and is connected to the exhaust reservoir 13.
- the exhaust port H communicates with the exhaust reservoir 13.
- the cylinder head 3 b is provided with a fuel injection valve (not shown).
- an in-cylinder pressure sensor (not shown) is provided in the vicinity of the fuel injection valve of the cylinder head 3b. The in-cylinder pressure sensor detects the pressure in the combustion chamber R1 and transmits the pressure to the control unit 300.
- the cylinder jacket 3c is a cylindrical member provided between the frame 2 and the cylinder liner 3a and into which the lower end portion of the cylinder liner 3a is inserted, and a scavenging chamber R2 is formed inside.
- the scavenging chamber R2 of the cylinder jacket 3c is connected to the scavenging air reservoir 12.
- the piston 4 has a substantially cylindrical shape, is connected to a piston rod 6 described later, and is disposed inside the cylinder liner 3a. Further, a piston ring (not shown) is provided on the outer peripheral surface of the piston 4, and the piston ring seals the gap between the piston 4 and the cylinder liner 3 a.
- the piston 4 slides in the cylinder liner 3a with the piston rod 6 due to the pressure fluctuation in the combustion chamber R1.
- the sliding direction of the piston 4 is the same as the central axis direction (vertical direction in FIG. 1) of the cylinder liner 3a.
- the exhaust valve unit 5 has an exhaust valve 5a, an exhaust valve housing 5b, and an exhaust valve drive unit 5c.
- the exhaust valve 5a is provided inside the cylinder head 3b, and closes the exhaust port H in the cylinder unit 3 by the exhaust valve drive unit 5c.
- the exhaust valve housing 5b is a cylindrical housing that accommodates the end of the exhaust valve 5a.
- the exhaust valve drive unit 5 c is an actuator that moves the exhaust valve 5 a in a direction along the stroke direction (sliding direction) of the piston 4.
- the piston rod 6 is an elongated member having one end (upper end) connected to the piston 4 and the other end (lower end) connected to the cross head pin 7a.
- the piston rod 6 of the present embodiment is a rod-like member.
- the end (lower end) of the piston rod 6 is inserted into the crosshead pin 7a, and the connecting rod 9 is connected so as to be rotatable.
- the piston rod 6 also has a rod-like main body 6a extending in the vertical direction, and a large diameter part 6b whose diameter at the end of the crosshead pin 7a is larger than that of the main body 6a See Figure 2).
- the large diameter portion 6b is also formed in a cylindrical shape.
- the crosshead 7 includes a crosshead pin 7a, a guide shoe 7b, and a lid member 7c.
- the side where the piston rod 6 is provided is the upper side
- the side where the plunger pump 8 c and the relief valve 8 f described later are provided is the lower side.
- the crosshead pin 7a is a cylindrical member that movably connects the piston rod 6 and the connecting rod 9 and operates in an insertion space (insertion recess) in which the end (large diameter portion 6b) of the piston rod 6 is inserted.
- a hydraulic chamber R3 (fluid chamber) in which supply and discharge of oil (working fluid) are performed is formed.
- the central axis of the cross head pin 7 a extends in a direction perpendicular to the sliding direction of the piston 4.
- the insertion recess is provided on the top of the crosshead pin 7a so as to open upward.
- the outer peripheral surface of the large diameter portion 6b is in fluid tight contact with the inner peripheral surface of the insertion recess.
- an outlet hole O penetrating along the axial direction of the crosshead pin 7a is formed below the center of the crosshead pin 7a.
- the outlet hole O is an opening through which the cooling oil having passed through a cooling flow passage (not shown) of the piston rod 6 is discharged.
- the crosshead pin 7a is provided with a supply flow passage R4 connecting the hydraulic pressure chamber R3 and the plunger pump 8c described later, and a relief flow passage R5 connecting the hydraulic pressure chamber R3 and the relief valve 8f described later .
- the guide shoe 7b is a member for rotatably supporting the cross head pin 7a, and moves on a guide rail (not shown) along the stroke direction of the piston 4 along with the cross head pin 7a.
- the guide shoe 7 b is provided in the frame 2.
- the movement of the guide shoe 7b along the guide rail restricts the movement of the crosshead pin 7a other than the linear direction along the stroke direction of the piston 4.
- the rotational motion of the cross head pin 7a about its central axis is also restricted.
- the lid member 7c is an annular member fixed to the upper portion of the crosshead pin 7a and into which the end of the piston rod 6 is inserted.
- the lid member 7c is provided at the opening peripheral edge portion of the insertion recess of the cross head pin 7a.
- the inner diameter of the lid member 7c is equal to the outer diameter of the main body 6a of the piston rod 6, and smaller than the outer diameter of the large diameter portion 6b.
- the large diameter portion 6 b is vertically movable in the insertion recess.
- a space between the inner surface of the insertion recess and the lower surface of the large diameter portion 6b constitutes a hydraulic pressure chamber R3.
- Such a crosshead 7 transmits the linear motion of the piston 4 to the connecting rod 9.
- the hydraulic unit 8 includes a supply pump 8a, a rocking pipe 8b, a plunger pump 8c, and a first check valve 8d and a second check valve 8e connected to the plunger pump 8c. , And a relief valve 8f.
- the piston rod 6, the crosshead 7, and the hydraulic unit 8 function as a variable compression device in the present disclosure.
- the supply pump 8a is a pump that pressurizes hydraulic oil supplied from a hydraulic oil tank (not shown) and supplies the hydraulic oil to the plunger pump 8c based on an instruction from the control unit 300.
- the supply pump 8a is driven by the power of the battery of the ship, and can operate before the combustion chamber R1 is supplied with liquid fuel.
- the swinging pipe 8b is a pipe connecting the supply pump 8a and the plunger pump 8c of each cylinder, and swings between the plunger pump 8c moving along with the cross head pin 7a and the fixed supply pump 8a. It is made possible.
- the plunger pump 8c is fixed to the cross head pin 7a, and includes a rod-like plunger 8c1, a cylindrical cylinder 8c2 slidably accommodating the plunger 8c1, and a plunger driving unit 8c3.
- the plunger pump 8c slides in the cylinder 8c2 by connecting the plunger 8c1 to the plunger driving unit 8c3, and pressurizes the hydraulic oil and supplies it to the hydraulic chamber R3.
- a first check valve 8d is provided at the discharge side opening of the hydraulic oil provided at the end, and a second check valve 8e is provided at the suction side opening provided on the side circumferential surface. It is provided.
- the plunger driving unit 8c3 is connected to the plunger 8c1 and reciprocates the plunger 8c1 based on an instruction from the control unit 300.
- the first check valve 8d is structured such that the valve body is biased toward the inside of the cylinder 8c2 by a biasing member (not shown) so as to close the valve, and the hydraulic oil supplied to the hydraulic chamber R3 is transmitted to the cylinder 8c2 It prevents the backflow to the back.
- the first check valve 8d when the pressure of the hydraulic oil in the cylinder 8c2 becomes equal to or greater than the biasing force (opening pressure) of the biasing member of the first check valve 8d, the valve body is pushed by the hydraulic oil. Open the valve.
- the second check valve 8e is biased toward the outside of the cylinder 8c2 by a biasing member (not shown) to prevent the hydraulic oil supplied to the cylinder 8c2 from flowing back to the supply pump 8a. .
- the valve body becomes hydraulic fluid. It opens by being pushed.
- the first check valve 8d has a valve opening pressure higher than that of the second check valve 8e, and is supplied from the supply pump 8a during steady-state operation operated at a preset compression ratio. It does not open due to the pressure of the hydraulic fluid.
- the relief valve 8f is provided on the cross head pin 7a, and has a main body 8f1 and a relief valve drive 8f2.
- the main body 8f1 is a valve connected to the hydraulic pressure chamber R3 via a relief flow path R5 and to a hydraulic oil tank (not shown).
- the relief valve drive unit 8f2 is connected to the valve body of the main body 8f1 and opens and closes the main body 8f1 based on an instruction from the control unit 300.
- the relief valve 8f is opened by the relief valve drive unit 8f2, whereby the hydraulic oil stored in the hydraulic pressure chamber R3 is returned to the hydraulic oil tank.
- the connecting rod 9 is an elongated member connected to the crosshead pin 7 a and connected to the crankshaft 11.
- the connecting rod 9 converts the linear motion of the piston 4 transmitted to the crosshead pin 7a into rotational motion.
- the crank angle sensor 10 is a sensor for measuring the crank angle of the crankshaft 11, and transmits a crank pulse signal for calculating the crank angle to the control unit 300.
- the crankshaft 11 is an elongated member connected to a connecting rod 9 provided in a cylinder, and transmits power to, for example, a screw or the like by being rotated by rotational motion transmitted by the connecting rod 9.
- the scavenging air reservoir 12 is provided between the cylinder jacket 3c and the supercharger 200, and the air pressurized by the supercharger 200 flows in.
- an air cooler 14 is provided inside the scavenging air reservoir 12.
- the exhaust reservoir 13 is a tubular member connected to the exhaust port H of each cylinder and connected to the turbocharger 200. The gas discharged from the exhaust port H is temporarily stored in the exhaust reservoir 13 and is thus supplied to the turbocharger 200 in a state where pulsation is suppressed.
- the air cooler 14 is a device that cools the air inside the scavenging gas reservoir 12.
- the supercharger 200 pressurizes air taken in from an intake port (not shown) by a turbine rotated by the gas discharged from the exhaust port H, via the scavenging air reservoir 12, the air cooler 14, and the scavenging chamber R2. It is an apparatus which supplies combustion chamber R1.
- the control unit 300 is a computer that controls the amount of supplied fuel and the like based on an operation and the like by the operator of the ship.
- the control unit 300 includes a central processing unit (CPU), a memory such as a random access memory (RAM) or a read only memory (ROM), and a storage device such as a solid state drive (SSD) or a hard disk drive (HDD). There is.
- the control unit 300 is connected to the position detection unit 400 by wire. Note that the control unit 300 may wirelessly communicate information with the position detection unit 400.
- the control unit 300 also controls the hydraulic unit 8 to change the compression ratio in the combustion chamber R1.
- control unit 300 acquires position information of piston rod 6 based on a signal from position detection unit 400, controls plunger pump 8c, supply pump 8a and relief valve 8f, and operates in hydraulic chamber R3. By adjusting the amount of oil, the position (the position in the sliding direction) of the piston rod 6 is changed to change the compression ratio.
- the control unit 300 of the present embodiment not only controls the operation of the engine 1 by adjusting the fuel supplied to the engine 1 or the like, but also has the function of the position acquisition device of the present disclosure. However, in addition to the control unit 300, a control device corresponding to the position acquisition device of the present disclosure may be provided.
- the position detection unit 400 includes a detection unit 410 and a detection unit 420.
- the to-be-detected part 410 is comprised by the two uneven part 411,412.
- the concavo-convex portions 411 and 412 are provided on the lower end side of the sliding surface of the piston 4 and are respectively constituted by a plurality of concavities and convexities formed at equal intervals in the sliding direction of the piston 4. That is, the widths in the sliding direction of the concave portion and the convex portion constituting the concavo-convex portions 411 and 412 are all equal. Further, the uneven portions 411 and 412 are provided adjacent to each other in the circumferential direction of the piston.
- the concavo-convex portions 411 and 412 are arranged so that the concavities and convexities equal to each other are arranged, and the positions of the concavities and convexities in the sliding direction of the piston 4 are offset by half the width of each concave.
- the shift amount of the position of each unevenness is not limited to half of the width of each recess, and may be set arbitrarily according to the resolution of the detection unit.
- the detected portion 410 is provided below (on the piston rod 6 side) the piston ring (not shown) provided on the piston 4. Thereby, the detection target portion 410 is not easily affected by the lubricating oil on the sliding surface of the piston 4.
- the detection unit 420 is disposed at the lower end side of the inner peripheral surface of the cylinder liner 3a at a position farther from the combustion chamber R1 than the scavenging port S, and is installed the same as or outside the cylinder liner wall. In the present embodiment, it is embedded and fixed to the lower end side of the inner peripheral surface of the cylinder liner 3a.
- the radially inner surface of the position detection unit 400 in the cylinder liner 3a may be provided flush with the inner circumferential surface of the cylinder liner 3a.
- the detection unit 420 is a sensor that generates an electric signal (a signal including positional information of the piston rod 6 (piston 4)) by a change in distance with the surface of the detection unit 410 accompanying the movement of the two detection units 410.
- the detection unit 420 examples include a photoelectric sensor, a laser sensor, and a proximity sensor such as an inductive sensor or a capacitive sensor. For this reason, the detection unit 420 can detect which of the concave and convex portions of the concavo-convex portions 411 and 412 is opposed to each other, thereby detecting the position of the piston 4 in the sliding direction.
- Such an engine system 100 is a device that causes the piston 4 to slide in the cylinder liner 3 a by igniting and detonating the fuel injected into the combustion chamber R1 from a fuel injection valve (not shown), and rotates the crankshaft 11. is there. More specifically, the fuel supplied to the combustion chamber R1 is mixed with the air flowing in from the scavenging port S, and then compressed by movement of the piston 4 toward the top dead center to raise the temperature, resulting in natural Ignite. In the case of liquid fuel, it is vaporized by temperature rise in the combustion chamber R1 and spontaneously ignited.
- the fuel in the combustion chamber R1 is rapidly ignited by natural ignition, and the pressure is applied to the piston 4 in the direction of the bottom dead center.
- the piston 4 moves in the bottom dead center direction
- the piston rod 6 is moved along with the piston 4, and the crankshaft 11 is rotated via the connecting rod 9.
- pressurized air flows from the scavenging port S into the combustion chamber R1.
- the exhaust port H is opened by driving the exhaust valve unit 5, and the exhaust gas in the combustion chamber R1 is pushed out to the exhaust reservoir 13 by the pressurized air.
- the control unit 300 drives the supply pump 8a to supply hydraulic oil to the plunger pump 8c. Then, the control unit 300 drives the plunger pump 8 c to press the hydraulic oil to a pressure capable of lifting the piston rod 6, and supplies the hydraulic oil to the hydraulic chamber R 3. The end (large diameter portion 6b) of the piston rod 6 is lifted by the pressure of the hydraulic fluid in the hydraulic chamber R3, and the top dead center position of the piston 4 is moved upward (exhaust port H side) accordingly.
- the relief valve 8f is driven by the control unit 300, and the hydraulic pressure chamber R3 and a hydraulic oil tank (not shown) are in communication. Then, the load of the piston rod 6 is applied to the hydraulic oil in the hydraulic chamber R3, and the hydraulic oil in the hydraulic chamber R3 is pushed out to the hydraulic oil tank via the relief valve 8f. As a result, the hydraulic oil in the hydraulic chamber R3 decreases, and the piston rod 6 is moved downward (toward the crankshaft 11), and the top dead center position of the piston 4 is moved downward accordingly.
- the resolution of the position detection by the detection part 420 is each It becomes half the length of the unevenness in the sliding direction of the piston 4.
- the control unit 300 receives the electrical signal of the detection unit 420, and calculates (acquires) the position of the piston 4 based on the electrical signal. Then, the control unit 300 controls the hydraulic unit 8 based on the position of the piston 4 and adjusts the position of the piston rod 6.
- the position detection unit 400 outputs a signal including position information in the moving direction of the piston 4, and the control unit 300 acquires position information of the piston 4.
- the control unit 300 can constantly monitor whether the position in the movement direction of the piston 4 matches the position of the piston 4 as a target, and can accurately adjust the position in the movement direction of the piston 4.
- the control unit 300 can control the variable compression device more stably by accurately grasping the position of the piston 4.
- the detection unit 420 is embedded in the cylinder liner 3 a that does not move relative to the frame 2.
- the detection unit 420 and the control unit 300 can be connected by wire. Therefore, there is no need to provide a wireless transmission device such as a telemeter, and installation becomes easy.
- two detection target portions 410 are provided, which are disposed so as to be shifted by a half wavelength in the sliding direction of the piston 4.
- the detecting portion 420 can reliably detect the detected portions 410.
- the position of the piston 4 can be detected with the half resolution of the uneven width in the sliding direction of the piston 4 as the minimum resolution, the position of the piston 4 can be detected with higher accuracy.
- the detection unit 420 is provided at a position farther from the combustion chamber R1 than the scavenging port S. As a result, the detection unit 420 can reduce the effects of heat and pressure in the combustion chamber R1.
- Second Embodiment A modification of the first embodiment is described as a second embodiment.
- symbol is attached
- the engine system 100 in the present embodiment does not have the position detection unit 400.
- the control unit 300 position acquisition device calculates the actual compression ratio based on the pressure in the combustion chamber R1 calculated from the signal from the in-cylinder pressure sensor (detection device) (not shown), Get the position of the piston 4
- the compression ratio ⁇ is expressed by the following equation 1.
- ⁇ represents a polytropic index.
- the control unit 300 calculates the compression ratio in the cylinder unit 3 based on the above equation 1 from the signal input from the in-cylinder pressure sensor. Further, the control unit 300 calculates the position of the piston 4 from the calculated compression ratio.
- the position of the piston 4 is acquired based on the in-cylinder pressure.
- the control unit 300 can constantly monitor whether the position in the movement direction of the piston 4 matches the position of the piston 4 as a target, and can accurately adjust the position in the movement direction of the piston 4.
- the control unit 300 can control the variable compression device more stably by accurately grasping the position of the piston 4.
- the piston rod 6 connected to the piston 4 is moved in the direction of increasing the compression ratio by being supplied with the pressurized hydraulic fluid (working fluid).
- a variable compression device (piston rod 6, cross head 7, and hydraulic unit 8) having a hydraulic chamber R3 (fluid chamber), a position detection unit 400 (detection device) that outputs a signal including positional information of the piston 4, And a controller 300 (position acquisition device) for acquiring the position of the piston 4 based on the above.
- the position detection unit 400 is configured such that at least a part (not-shown in-cylinder pressure sensor) is provided on the cylinder liner 3 a in which the piston 4 slides and detects the position of the piston 4 in the sliding direction There is.
- the position detection unit 400 has a detected unit 410 provided on the piston 4 and a detection unit 420 provided on the cylinder liner 3 a.
- a plurality of position detection units 400 are provided in the circumferential direction on the sliding surface of the piston 4.
- the detection unit 420 is provided at a position farther from the combustion chamber R1 than the scavenging port S of the cylinder liner 3a in the sliding direction of the piston 4.
- the detection unit 420 is provided such that the scavenging port S of the cylinder liner 3 a is located between the detection unit 420 and the combustion chamber R ⁇ b> 1 in the sliding direction of the piston 4.
- the position detection part 400 acquired the position of piston 4 by detecting an unevenness
- this indication is not limited to this.
- the position detection unit 400 has the detection unit 410 in which the magnetic members are arranged at equal intervals in the sliding direction of the piston 4 and the detection unit 420 (magnetic sensor) that detects a change in the magnetic field.
- the detection unit 420 of the position detection unit 400 is a sensor (proximity sensor etc.) capable of detecting the lower end of the piston 4 etc., only this detection unit 420 (part of the position detection unit 400) It may be provided in
- the installation location, position, and number of the detection target 410 are not limited to the above embodiment.
- the to-be-detected part 410 may be provided in three or more places, or may be provided only in one place.
- a plurality of detection units 420 are provided, and a plurality of detection target units 410 are opposed to each other across the center of piston 4 (the center of piston 4 in the radial direction of cylinder liner 3a) ) May be provided. In this case, it is also possible to detect the inclination of the piston 4 with respect to the sliding direction by increasing the resolution of position detection by the detection target portion 410 and the detection portion 420.
- the present disclosure is applied to an engine system provided with a variable compression device having a fluid chamber in which a piston rod connected to a piston is moved in a direction to increase a compression ratio by being supplied with a boosted working fluid. it can.
Landscapes
- Engineering & Computer Science (AREA)
- General Engineering & Computer Science (AREA)
- Chemical & Material Sciences (AREA)
- Combustion & Propulsion (AREA)
- Mechanical Engineering (AREA)
- Output Control And Ontrol Of Special Type Engine (AREA)
- Pistons, Piston Rings, And Cylinders (AREA)
Abstract
このエンジンシステム(100)は、昇圧された作動流体が供給されることで、ピストン(4)と接続されるピストンロッド(6)が圧縮比を高める方向に移動される流体室(R3)を有する可変圧縮装置(6、7及び8)と、ピストンの位置情報を含む信号を出力する検出装置(400)と、上記信号に基づいてピストンの位置を取得する位置取得装置(300)とを有する。
Description
本開示は、エンジンシステムに関する。
本願は、2017年10月27日に日本に出願された特願2017-207964号に基づき優先権を主張し、その内容をここに援用する。
本願は、2017年10月27日に日本に出願された特願2017-207964号に基づき優先権を主張し、その内容をここに援用する。
例えば、特許文献1には、クロスヘッドを有する大型往復ピストン燃焼エンジンが開示されている。特許文献1の大型往復ピストン燃焼エンジンは、重油などの液体燃料と天然ガス等の気体燃料との両方での稼働が可能とされるデュアルフュエルエンジンである。特許文献1の大型往復ピストン燃焼エンジンは、液体燃料による稼働に適する圧縮比と気体燃料による稼働に適する圧縮比との双方に対応するため、油圧によりピストンロッドを移動させることで圧縮比を変更させる調整機構をクロスヘッド部分に設けている。
上述のような圧縮比を変更する圧縮調整装置を有するエンジンシステムは、ピストンロッドの移動方向における位置を変更することにより、ピストンの下死点位置及び上死点位置を変更し、圧縮比を調整している。このような圧縮比の調整は、操縦者の操作等に基づいてエンジンシステムの制御装置が行っている。しかしながら、制御装置は、ピストンロッドの位置を把握しておらず、正確に圧縮比を調整することが難しい場合がある。
本開示は、上述する問題点に鑑みてなされたもので、可変圧縮装置を有するエンジンシステムにおいて、正確に圧縮比を取得することを目的とする。
本開示の第1の態様のエンジンシステムは、昇圧された作動流体が供給されることで、ピストンと接続されるピストンロッドが圧縮比を高める方向に移動される流体室を有する可変圧縮装置と、上記ピストンの位置情報を含む信号を出力する検出装置と、上記信号に基づいて上記ピストンの位置を取得する位置取得装置とを有する。
本開示の第2の態様は、上記第1の態様において、上記検出装置は、少なくとも一部が、上記ピストンが内部で摺動するシリンダライナに設けられ、上記ピストンの摺動方向における位置を検出するように構成されている。
本開示の第3の態様は、上記第2の態様において、上記検出装置は、上記ピストンに設けられた被検出部と、上記シリンダライナに設けられた検出部とを有する。
本開示の第4の態様は、上記第3の態様において、上記被検出部は、上記ピストンの摺動面において、周方向に複数設けられる。
本開示の第5の態様として、上記第3または4の態様において、上記検出部は、上記ピストンの摺動方向において、上記シリンダライナの掃気ポートよりも燃焼室から離れた位置に設けられる。
本開示によれば、検出装置が、ピストンの移動方向(摺動方向)における位置情報を含む信号を出力し、位置取得装置が、ピストンの位置情報を取得すると共に、エンジンシステムに備えられた制御部が、上記位置情報に基づいて、流体室内の圧力を調整する昇圧機構を制御する。これにより、制御部は、ピストンの移動方向における正確な位置を取得し、目標とするピストンの位置と合っているかを常に監視することができる。さらに、制御部は、ピストンの位置を正確に把握することにより、より安定的に可変圧縮装置を制御することができる。
以下、図面を参照して、本開示におけるエンジンシステム100の一実施形態について説明する。
[第1実施形態]
本実施形態のエンジンシステム100は、例えば大型タンカなど船舶に搭載され、図1に示すように、エンジン1と、過給機200と、制御部300(位置取得装置)と、位置検出部400(検出装置)とを有している。なお、本実施形態においては、過給機200を補機として捉え、エンジン1(主機)と別体として説明する。但し、過給機200をエンジン1の一部として構成することも可能である。なお、過給機200は、本実施形態のエンジンシステム100に必須の構成要素ではなく、エンジンシステム100に設けられずともよい。
図1は、エンジンシステム100に設けられた後述する円筒状のシリンダライナ3aの中心軸に沿った縦断面図である。図1において、後述する排気弁ユニット5が設けられている側を上側、後述するクランク軸11が設けられている側を下側と称する場合がある。シリンダライナ3aの中心軸方向から見た図を平面視と称する場合がある。
本実施形態のエンジンシステム100は、例えば大型タンカなど船舶に搭載され、図1に示すように、エンジン1と、過給機200と、制御部300(位置取得装置)と、位置検出部400(検出装置)とを有している。なお、本実施形態においては、過給機200を補機として捉え、エンジン1(主機)と別体として説明する。但し、過給機200をエンジン1の一部として構成することも可能である。なお、過給機200は、本実施形態のエンジンシステム100に必須の構成要素ではなく、エンジンシステム100に設けられずともよい。
図1は、エンジンシステム100に設けられた後述する円筒状のシリンダライナ3aの中心軸に沿った縦断面図である。図1において、後述する排気弁ユニット5が設けられている側を上側、後述するクランク軸11が設けられている側を下側と称する場合がある。シリンダライナ3aの中心軸方向から見た図を平面視と称する場合がある。
エンジン1は、多気筒のユニフロー掃気ディーゼルエンジンとされ、天然ガス等の気体燃料を重油などの液体燃料と共に燃焼させるガス運転モードと、重油などの液体燃料を燃焼させるディーゼル運転モードとを実行可能なデュアルフュエルエンジンである。なお、ガス運転モードでは、気体燃料のみを燃焼させても良い。このようなエンジン1は、架構2と、シリンダ部3と、ピストン4と、排気弁ユニット5と、ピストンロッド6と、クロスヘッド7と、油圧部8(昇圧機構)と、連接棒9と、クランク角センサ10と、クランク軸11と、掃気溜12と、排気溜13と、空気冷却器14とを有している。また、シリンダ部3、ピストン4、排気弁ユニット5及びピストンロッド6により、気筒が構成されている。
架構2は、エンジン1の全体を支持する強度部材であり、クロスヘッド7、油圧部8及び連接棒9が収容されている。また、架構2は、内部において、クロスヘッド7の後述するクロスヘッドピン7aが往復動可能とされている。
シリンダ部3は、円筒状のシリンダライナ3aと、シリンダヘッド3bとシリンダジャケット3cとを有している。シリンダライナ3aは、円筒状の部材であり、ピストン4との摺動面が内側(内周面)に形成されている。このようなシリンダライナ3aの内周面とピストン4とにより囲まれた空間が燃焼室R1とされている。また、シリンダライナ3aの下部には、複数の掃気ポートSが形成されている。掃気ポートSは、シリンダライナ3aの周面に沿って配列された開口であり、シリンダジャケット3c内部の掃気室R2とシリンダライナ3aの内側とを連通している。シリンダヘッド3bは、シリンダライナ3aの上端部に設けられた蓋部材である。シリンダヘッド3bは、平面視において中央部に排気ポートHが形成され、排気溜13と接続されている。排気ポートHは、排気溜13に連通している。また、シリンダヘッド3bには、不図示の燃料噴射弁が設けられている。さらに、シリンダヘッド3bの燃料噴射弁の近傍には、不図示の筒内圧センサが設けられている。筒内圧センサは、燃焼室R1内の圧力を検出し、制御部300へと送信している。シリンダジャケット3cは、架構2とシリンダライナ3aとの間に設けられ、シリンダライナ3aの下端部が挿入された円筒状の部材であり、内部に掃気室R2が形成されている。また、シリンダジャケット3cの掃気室R2は、掃気溜12と接続されている。
ピストン4は、略円柱状とされ、後述するピストンロッド6と接続されてシリンダライナ3aの内側に配置されている。また、ピストン4の外周面には不図示のピストンリングが設けられ、ピストンリングにより、ピストン4とシリンダライナ3aとの間隙を封止している。ピストン4は、燃焼室R1における圧力の変動により、ピストンロッド6を伴ってシリンダライナ3a内を摺動する。ピストン4の摺動方向は、シリンダライナ3aの中心軸方向(図1の上下方向)と同一である。
排気弁ユニット5は、排気弁5aと、排気弁筐5bと、排気弁駆動部5cとを有している。排気弁5aは、シリンダヘッド3bの内側に設けられ、排気弁駆動部5cにより、シリンダ部3内の排気ポートHを閉塞する。排気弁筐5bは、排気弁5aの端部を収容する円筒形の筐体である。排気弁駆動部5cは、排気弁5aをピストン4のストローク方向(摺動方向)に沿う方向に移動させるアクチュエータである。
ピストンロッド6は、一端(上端)がピストン4と接続され、他端(下端)がクロスヘッドピン7aと連結された長尺状部材である。本実施形態のピストンロッド6は、棒状部材である。ピストンロッド6の端部(下端部)は、クロスヘッドピン7aに挿入され、連接棒9が回転可能となるように連結されている。また、ピストンロッド6は、上下方向に延びる棒状の本体部6aと、クロスヘッドピン7a側端部の一部の径が本体部6aよりも太く形成された太径部6bとを有している(図2参照)。太径部6bも円柱状に形成されている。
クロスヘッド7は、図1及び図2に示すように、クロスヘッドピン7aと、ガイドシュー7bと、蓋部材7cとを有している。なお、図2において、ピストンロッド6が設けられている側が上側であり、後述するプランジャポンプ8cやリリーフ弁8fが設けられている側が下側である。クロスヘッドピン7aは、ピストンロッド6と連接棒9とを移動可能に連結する円柱状部材であり、ピストンロッド6の端部(太径部6b)が挿入される挿入空間(挿入凹部)に、作動油(作動流体)の供給及び排出が行われる油圧室R3(流体室)が形成される。クロスヘッドピン7aの中心軸は、ピストン4の摺動方向と直交する方向に延びている。上記挿入凹部は、クロスヘッドピン7aの上部に、上方に向けて開口して設けられている。太径部6bの外周面は、上記挿入凹部の内周面に液密に接している。クロスヘッドピン7aには、その中心よりも下側に、クロスヘッドピン7aの軸方向に沿って貫通する出口孔Oが形成されている。出口孔Oは、ピストンロッド6の不図示の冷却流路を通過した冷却油が排出される開口である。また、クロスヘッドピン7aには、油圧室R3と後述するプランジャポンプ8cとを接続する供給流路R4と、油圧室R3と後述するリリーフ弁8fとを接続するリリーフ流路R5とが設けられている。
ガイドシュー7bは、クロスヘッドピン7aを回動可能に支持する部材であり、クロスヘッドピン7aに伴ってピストン4のストローク方向に沿って不図示のガイドレール上を移動する。ガイドシュー7bは、架構2内に設けられている。ガイドシュー7bがガイドレールに沿って移動することにより、クロスヘッドピン7aは、ピストン4のストローク方向に沿う直線方向以外への移動が規制される。クロスヘッドピン7aは、その中心軸回りの回転運動も規制されている。蓋部材7cは、クロスヘッドピン7aの上部に固定され、ピストンロッド6の端部が挿入される環状部材である。蓋部材7cは、クロスヘッドピン7aの上記挿入凹部の開口周縁部に設けられている。蓋部材7cの内径は、ピストンロッド6の本体部6aの外径と同等であり、太径部6bの外径よりも小さい。太径部6bは、上記挿入凹部内を上下方向に移動可能となっている。上記挿入凹部の内面と、太径部6bの下面と、の間の空間が、油圧室R3を構成する。このようなクロスヘッド7は、ピストン4の直線運動を連接棒9へと伝達している。
図2に示すように、油圧部8は、供給ポンプ8aと、揺動管8bと、プランジャポンプ8cと、プランジャポンプ8cに接続されている第1逆止弁8d及び第2逆止弁8eと、リリーフ弁8fとを有している。また、ピストンロッド6、クロスヘッド7及び油圧部8は、本開示における可変圧縮装置として機能する。
供給ポンプ8aは、制御部300からの指示に基づいて、不図示の作動油タンクから供給される作動油を昇圧してプランジャポンプ8cへと供給するポンプである。供給ポンプ8aは、船舶のバッテリの電力により駆動され、燃焼室R1に液体燃料が供給されるよりも前に稼働することが可能である。揺動管8bは、供給ポンプ8aと各気筒のプランジャポンプ8cとを接続する配管であり、クロスヘッドピン7aに伴って移動するプランジャポンプ8cと、固定された供給ポンプ8aとの間において、揺動可能とされている。
プランジャポンプ8cは、クロスヘッドピン7aに固定されており、棒状のプランジャ8c1と、プランジャ8c1を摺動可能に収容する筒状のシリンダ8c2と、プランジャ駆動部8c3とを有している。プランジャポンプ8cは、プランジャ8c1がプランジャ駆動部8c3と接続されることで、シリンダ8c2内を摺動し、作動油を昇圧して油圧室R3へと供給する。また、シリンダ8c2には、端部に設けられた作動油の吐出側の開口に第1逆止弁8dが設けられ、側周面に設けられた吸入側の開口に第2逆止弁8eが設けられている。プランジャ駆動部8c3は、プランジャ8c1に接続され、制御部300からの指示に基づいてプランジャ8c1を往復動させる。
第1逆止弁8dは、シリンダ8c2の内側に向けて弁体が不図示の付勢部材によって付勢されることで閉弁する構造とされ、油圧室R3に供給された作動油がシリンダ8c2へと逆流することを防止している。また、第1逆止弁8dは、シリンダ8c2内の作動油の圧力が第1逆止弁8dの付勢部材の付勢力(開弁圧力)以上となると、弁体が作動油に押されることにより開弁する。第2逆止弁8eは、シリンダ8c2の外側に向けて不図示の付勢部材によって付勢されており、シリンダ8c2に供給された作動油が供給ポンプ8aへと逆流することを防止している。また、第2逆止弁8eは、供給ポンプ8aから供給される作動油の圧力が第2逆止弁8eの付勢部材の付勢力(開弁圧力)以上となると、弁体が作動油に押されることにより開弁する。なお、第1逆止弁8dは、開弁圧力が第2逆止弁8eの開弁圧力よりも高く、予め設定された圧縮比で運転される定常運転時においては、供給ポンプ8aから供給される作動油の圧力により開弁することはない。
リリーフ弁8fは、クロスヘッドピン7aに設けられ、本体部8f1と、リリーフ弁駆動部8f2とを有している。本体部8f1は、リリーフ流路R5を介して油圧室R3に、及び不図示の作動油タンクに接続される弁である。リリーフ弁駆動部8f2は、本体部8f1の弁体に接続され、制御部300からの指示に基づいて本体部8f1を開閉弁する。リリーフ弁8fがリリーフ弁駆動部8f2により開弁することで、油圧室R3に貯留された作動油が作動油タンクに戻される。
図1に示すように、連接棒9は、クロスヘッドピン7aと連結されると共にクランク軸11と連結されている長尺状部材である。連接棒9は、クロスヘッドピン7aに伝えられたピストン4の直線運動を回転運動に変換している。クランク角センサ10は、クランク軸11のクランク角を計測するためのセンサであり、制御部300へとクランク角を算出するためのクランクパルス信号を送信している。
クランク軸11は、気筒に設けられる連接棒9に接続された長尺状の部材であり、それぞれの連接棒9により伝えられる回転運動により回転されることで、例えばスクリュー等に動力を伝える。掃気溜12は、シリンダジャケット3cと過給機200との間に設けられ、過給機200により加圧された空気が流入する。また、掃気溜12には、空気冷却器14が内部に設けられている。排気溜13は、各気筒の排気ポートHと接続されると共に過給機200と接続される管状部材である。排気ポートHより排出されるガスは、排気溜13に一時的に貯留されることにより、脈動を抑制した状態で過給機200へと供給される。空気冷却器14は、掃気溜12内部の空気を冷却する装置である。
過給機200は、排気ポートHより排出されたガスにより回転されるタービンにより、不図示の吸気ポートから吸入した空気を加圧して、掃気溜12、空気冷却器14及び掃気室R2を介して燃焼室R1に供給する装置である。
制御部300は、船舶の操縦者による操作等に基づいて、燃料の供給量等を制御するコンピュータである。制御部300は、CPU(Central Processing Unit)、RAM(Random Access Memory)やROM(Read Only Memory)といったメモリ、及びSSD(Solid State Drive)やHDD(Hard Disk Drive)といった記憶装置等から構成されている。制御部300は、位置検出部400と有線により接続されている。なお、制御部300が位置検出部400と無線により情報伝達可能とされていてもよい。また、制御部300は、油圧部8を制御することにより、燃焼室R1における圧縮比を変更する。具体的には、制御部300は、位置検出部400からの信号に基づいてピストンロッド6の位置情報を取得し、プランジャポンプ8c、供給ポンプ8a及びリリーフ弁8fを制御し、油圧室R3における作動油の量を調整することにより、ピストンロッド6の位置(摺動方向の位置)を変更させて圧縮比を変更する。
なお、本実施形態の制御部300は、エンジン1に供給される燃料を調整する等してエンジン1の動作を制御するのみならず、本開示の位置取得装置の機能も有している。しかし、制御部300の他に、本開示の位置取得装置に相当する制御装置が設けられていてもよい。
なお、本実施形態の制御部300は、エンジン1に供給される燃料を調整する等してエンジン1の動作を制御するのみならず、本開示の位置取得装置の機能も有している。しかし、制御部300の他に、本開示の位置取得装置に相当する制御装置が設けられていてもよい。
位置検出部400は、図1及び図3に示すように、被検出部410と、検出部420とを有している。被検出部410は、2つの凹凸部411、412により構成されている。凹凸部411、412は、ピストン4の摺動面下端側に設けられ、それぞれ、ピストン4の摺動方向に向けて等間隔で形成された複数の凹凸により構成されている。すなわち、凹凸部411、412を構成する凹部及び凸部の摺動方向の幅は、全て同等となっている。また、凹凸部411、412は、ピストンの周方向において、隣接して設けられている。さらに、凹凸部411、412は、互いに等しい凹凸が配置されると共に、ピストン4の摺動方向において、それぞれの凹凸の位置が各凹部の幅の半分量だけずれるように設けられている。それぞれの凹凸の位置のずれ量は、各凹部の幅の半分量に限らず、検出部の分解能に応じて任意に設定してもよい。なお、被検出部410は、ピストン4に設けられるピストンリング(不図示)よりも下方(ピストンロッド6側)に設けられている。これにより、被検出部410は、ピストン4の摺動面における潤滑油の影響を受けにくい。
検出部420は、掃気ポートSよりも燃焼室R1から離れた位置であるシリンダライナ3aの内周面下端側であって、シリンダライナ壁面と同じか若しくは外側に設置される。本実施形態では、シリンダライナ3aの内周面下端側に埋設されて固定されている。位置検出部400の、シリンダライナ3aにおける径方向内側の内面は、シリンダライナ3aの内周面と面一になるように設けられてもよい。検出部420は、2つの被検出部410の移動に伴う被検出部410の表面との距離の変化により電気信号(ピストンロッド6(ピストン4)の位置情報を含む信号)を発生させるセンサである。検出部420としては、例えば、光電センサ、レーザセンサ、及び誘導型や静電容量型といった近接センサが挙げられる。このため、検出部420は、凹凸部411、412の凹部及び凸部のいずれが対向しているかを検出可能であり、よってピストン4の摺動方向の位置を検出可能である。
このようなエンジンシステム100は、不図示の燃料噴射弁より燃焼室R1に噴射された燃料を着火、爆発させることによりピストン4をシリンダライナ3a内で摺動させ、クランク軸11を回転させる装置である。詳述すると、燃焼室R1に供給された燃料は、掃気ポートSより流入した空気と混合された後、ピストン4が上死点方向に向けて移動することにより圧縮されて温度が上昇し、自然着火する。また、液体燃料の場合には、燃焼室R1において温度上昇することにより気化し、自然着火する。
そして、燃焼室R1内の燃料が自然着火することで急激に膨張し、ピストン4には下死点方向に向けた圧力がかかる。これにより、ピストン4が下死点方向に移動し、ピストン4に伴ってピストンロッド6が移動され、連接棒9を介してクランク軸11が回転される。さらに、ピストン4が下死点に移動されることで、掃気ポートSより燃焼室R1へと加圧空気が流入する。この際、排気弁ユニット5が駆動することで排気ポートHが開き、燃焼室R1内の排気ガスが、加圧空気により排気溜13へと押し出される。
圧縮比を大きくする場合には、制御部300により供給ポンプ8aが駆動され、プランジャポンプ8cに作動油が供給される。そして、制御部300は、プランジャポンプ8cを駆動して作動油を、ピストンロッド6を持ち上げることが可能な圧力となるまで加圧し、油圧室R3へと作動油を供給する。油圧室R3内の作動油の圧力により、ピストンロッド6の端部(太径部6b)が持ち上がり、これに伴ってピストン4の上死点位置が上方(排気ポートH側)に移動される。
圧縮比を小さくする場合には、制御部300によりリリーフ弁8fが駆動され、油圧室R3と不図示の作動油タンクとが連通状態となる。そして、ピストンロッド6の荷重が油圧室R3の作動油にかかり、油圧室R3内の作動油がリリーフ弁8fを介して作動油タンクへと押し出される。これにより、油圧室R3の作動油が減少し、ピストンロッド6が下方(クランク軸11側)に移動され、これに伴ってピストン4の上死点位置が下方に移動される。
続いて、本実施形態におけるピストンロッド6の位置調整方法について説明する。
ピストンロッド6の移動に伴ってピストン4が移動されると、被検出部410の凹凸が相対的に移動されることにより、検出部420が検出する被検出部410との距離が変化する。検出部420は、このような凹凸の変化、すなわち被検出部410の表面との相対的な距離の変化を電気信号として制御部300に出力する。なお、2つの被検出部410が各凹部の幅の半分量だけずれるように配置され、それぞれの被検出部410の磁界を検出しているため、検出部420による位置検出の分解能は、それぞれの凹凸のピストン4摺動方向における幅の半分の長さとなる。
ピストンロッド6の移動に伴ってピストン4が移動されると、被検出部410の凹凸が相対的に移動されることにより、検出部420が検出する被検出部410との距離が変化する。検出部420は、このような凹凸の変化、すなわち被検出部410の表面との相対的な距離の変化を電気信号として制御部300に出力する。なお、2つの被検出部410が各凹部の幅の半分量だけずれるように配置され、それぞれの被検出部410の磁界を検出しているため、検出部420による位置検出の分解能は、それぞれの凹凸のピストン4摺動方向における幅の半分の長さとなる。
制御部300は、検出部420の電気信号を受信し、当該電気信号に基づいて、ピストン4の位置を算出(取得)する。そして、制御部300は、ピストン4の位置に基づいて、油圧部8の制御を行い、ピストンロッド6の位置調整を行う。
このような本実施形態におけるエンジンシステム100によれば、位置検出部400により、ピストン4の移動方向における位置情報を含む信号を出力し、制御部300により、ピストン4の位置情報を取得する。これにより、制御部300は、ピストン4の移動方向における位置が、目標とするピストン4の位置と合っているかを常に監視し、ピストン4の移動方向における位置を正確に調整することができる。さらに、制御部300は、ピストン4の位置を正確に把握することにより、より安定的に可変圧縮装置を制御することができる。
さらに、本実施形態におけるエンジンシステム100においては、架構2に対して相対移動することのないシリンダライナ3aに検出部420を埋設している。これにより、検出部420と制御部300とを有線接続することができる。したがって、テレメータ等の無線送信装置を設ける必要がなく、設置が容易となる。
また、本実施形態におけるエンジンシステム100においては、ピストン4の摺動方向において半波長分ずらして配置された2つの被検出部410が設けられている。被検出部410を複数設けることにより、検出部420は、確実に被検出部410を検出することができる。また、凹凸のピストン4の摺動方向における幅の半分の長さを最低分解能として、ピストン4の位置を検出することができるため、より高精度にピストン4の位置を検出することができる。
また、本実施形態においては、検出部420が掃気ポートSよりも燃焼室R1から離れた位置に設けられている。これにより、検出部420が燃焼室R1における熱及び圧力の影響を小さくすることができる。
[第2実施形態]
上記第1実施形態の変形例を第2実施形態として説明する。なお、上記第1実施形態と同一の構成の部材については、同一の符号を付し、説明を省略する。
本実施形態におけるエンジンシステム100は、位置検出部400を有していない。このような構成において、制御部300(位置取得装置)は、不図示の筒内圧センサ(検出装置)からの信号から算出される燃焼室R1内圧力に基づいて、実際の圧縮比を算出し、ピストン4の位置を取得する。
上記第1実施形態の変形例を第2実施形態として説明する。なお、上記第1実施形態と同一の構成の部材については、同一の符号を付し、説明を省略する。
本実施形態におけるエンジンシステム100は、位置検出部400を有していない。このような構成において、制御部300(位置取得装置)は、不図示の筒内圧センサ(検出装置)からの信号から算出される燃焼室R1内圧力に基づいて、実際の圧縮比を算出し、ピストン4の位置を取得する。
ピストン4が下死点に位置するときの筒内圧をP0、ピストン4が上死点に位置するときの筒内圧をP1としたとき、圧縮比εは、下記式1で示される。なおκは、ポリトロープ指数を示す。
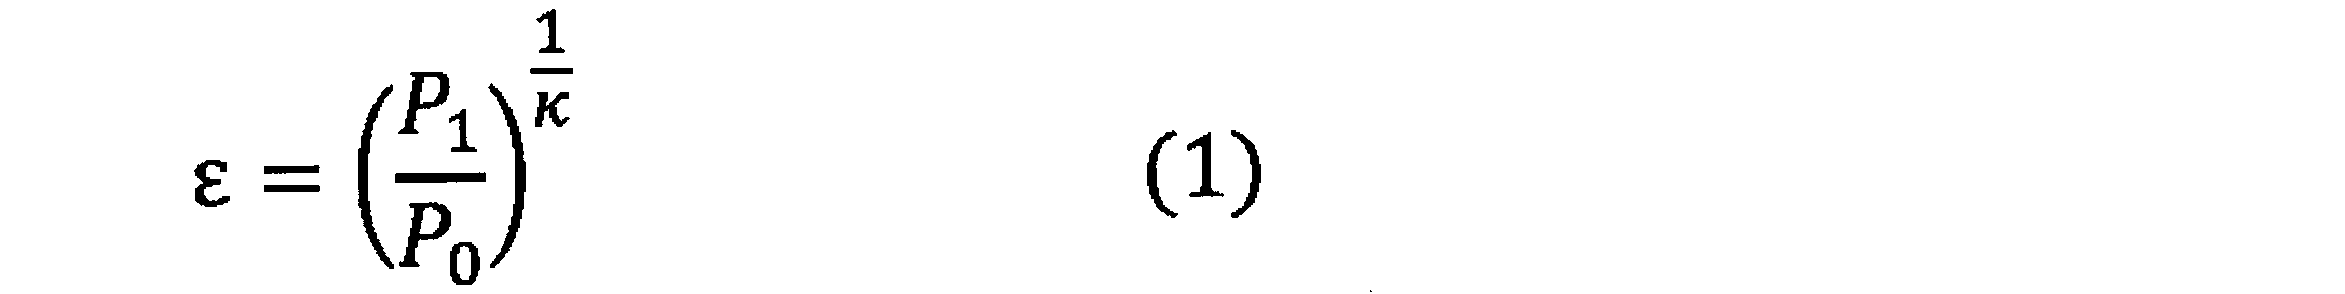
制御部300は、筒内圧センサから入力される信号から上記式1に基づいてシリンダ部3における圧縮比を算出する。さらに、制御部300は、算出された圧縮比からピストン4の位置を算出する。
このような本実施形態におけるエンジンシステム100によれば、筒内圧に基づいて、ピストン4の位置を取得する。これにより、制御部300は、ピストン4の移動方向における位置が、目標とするピストン4の位置と合っているかを常に監視し、ピストン4の移動方向における位置を正確に調整することができる。さらに、制御部300は、ピストン4の位置を正確に把握することにより、より安定的に可変圧縮装置を制御することができる。
上記第1及び第2実施形態において、エンジンシステム100は、昇圧された作動油(作動流体)が供給されることで、ピストン4と接続されるピストンロッド6が圧縮比を高める方向に移動される油圧室R3(流体室)を有する可変圧縮装置(ピストンロッド6、クロスヘッド7及び油圧部8)と、ピストン4の位置情報を含む信号を出力する位置検出部400(検出装置)と、上記信号に基づいてピストン4の位置を取得する制御部300(位置取得装置)とを有している。
位置検出部400は、少なくとも一部(不図示の筒内圧センサ)が、ピストン4が内部で摺動するシリンダライナ3aに設けられ、ピストン4の摺動方向における位置を検出するように構成されている。
位置検出部400は、ピストン4に設けられた被検出部410と、シリンダライナ3aに設けられた検出部420とを有する。
位置検出部400は、ピストン4の摺動面において、周方向に複数設けられる。
検出部420は、ピストン4の摺動方向において、シリンダライナ3aの掃気ポートSよりも燃焼室R1から離れた位置に設けられる。言い換えれば、検出部420は、シリンダライナ3aの掃気ポートSが、ピストン4の摺動方向において検出部420と燃焼室R1との間に位置するように設けられている。
位置検出部400は、少なくとも一部(不図示の筒内圧センサ)が、ピストン4が内部で摺動するシリンダライナ3aに設けられ、ピストン4の摺動方向における位置を検出するように構成されている。
位置検出部400は、ピストン4に設けられた被検出部410と、シリンダライナ3aに設けられた検出部420とを有する。
位置検出部400は、ピストン4の摺動面において、周方向に複数設けられる。
検出部420は、ピストン4の摺動方向において、シリンダライナ3aの掃気ポートSよりも燃焼室R1から離れた位置に設けられる。言い換えれば、検出部420は、シリンダライナ3aの掃気ポートSが、ピストン4の摺動方向において検出部420と燃焼室R1との間に位置するように設けられている。
以上、図面を参照しながら本開示の好適な実施形態について説明したが、本開示は上記実施形態に限定されるものではない。上述した実施形態において示した各構成部材の諸形状や組み合わせ等は一例であって、本開示の趣旨から逸脱しない範囲において設計要求等に基づき種々変更可能である。
上記実施形態においては、位置検出部400は、凹凸を検出することでピストン4の位置を取得したが、本開示はこれに限定されない。例えば、位置検出部400は、磁性部材がピストン4摺動方向に向けて等間隔で配置された被検出部410と、磁界の変化を検出する検出部420(磁気センサ)とを有してもよい。
また、位置検出部400の検出部420が、ピストン4の下端等を検出可能なセンサ(近接センサ等)である場合は、この検出部420(位置検出部400の一部)のみがシリンダライナ3aに設けられる構成であってもよい。
また、位置検出部400の検出部420が、ピストン4の下端等を検出可能なセンサ(近接センサ等)である場合は、この検出部420(位置検出部400の一部)のみがシリンダライナ3aに設けられる構成であってもよい。
また、被検出部410の設置個所、位置、数量は、上記実施形態に限定されない。被検出部410は、3箇所以上に設けられても、1箇所のみに設けられてもよい。さらに、検出部420が複数設けられ、複数の被検出部410がピストン4の中心(シリンダライナ3aの径方向におけるピストン4の中心)を挟んでそれぞれ互いに対向する位置(上記径方向で対向する位置)に設けられてもよい。この場合、被検出部410及び検出部420による位置検出の分解能を上げることにより、ピストン4の摺動方向に対する傾きを検出することも可能である。
本開示は、昇圧された作動流体が供給されることで、ピストンと接続されるピストンロッドが圧縮比を高める方向に移動される流体室を有する可変圧縮装置を備えたエンジンシステムに利用することができる。
1 エンジン
2 架構
3 シリンダ部
3a シリンダライナ
3b シリンダヘッド
3c シリンダジャケット
4 ピストン
5 排気弁ユニット
5a 排気弁
5b 排気弁筐
5c 排気弁駆動部
6 ピストンロッド
7 クロスヘッド
7a クロスヘッドピン
7b ガイドシュー
7c 蓋部材
8 油圧部
8a 供給ポンプ
8b 揺動管
8c プランジャポンプ
8c1 プランジャ
8c2 シリンダ
8c3 プランジャ駆動部
8d 第1逆止弁
8e 第2逆止弁
8f リリーフ弁
8f1 本体部
8f2 リリーフ弁駆動部
9 連接棒
10 クランク角センサ
11 クランク軸
12 掃気溜
13 排気溜
14 空気冷却器
100 エンジンシステム
200 過給機
300 制御部(位置取得装置)
400 位置検出部(検出装置)
410 被検出部
411 凹凸部
412 凹凸部
420 検出部
H 排気ポート
O 出口孔
R1 燃焼室
R2 掃気室
R3 油圧室
R4 供給流路
R5 リリーフ流路
R6 補助流路
S 掃気ポート
2 架構
3 シリンダ部
3a シリンダライナ
3b シリンダヘッド
3c シリンダジャケット
4 ピストン
5 排気弁ユニット
5a 排気弁
5b 排気弁筐
5c 排気弁駆動部
6 ピストンロッド
7 クロスヘッド
7a クロスヘッドピン
7b ガイドシュー
7c 蓋部材
8 油圧部
8a 供給ポンプ
8b 揺動管
8c プランジャポンプ
8c1 プランジャ
8c2 シリンダ
8c3 プランジャ駆動部
8d 第1逆止弁
8e 第2逆止弁
8f リリーフ弁
8f1 本体部
8f2 リリーフ弁駆動部
9 連接棒
10 クランク角センサ
11 クランク軸
12 掃気溜
13 排気溜
14 空気冷却器
100 エンジンシステム
200 過給機
300 制御部(位置取得装置)
400 位置検出部(検出装置)
410 被検出部
411 凹凸部
412 凹凸部
420 検出部
H 排気ポート
O 出口孔
R1 燃焼室
R2 掃気室
R3 油圧室
R4 供給流路
R5 リリーフ流路
R6 補助流路
S 掃気ポート
Claims (5)
- 昇圧された作動流体が供給されることで、ピストンと接続されるピストンロッドが圧縮比を高める方向に移動される流体室を有する可変圧縮装置と、
前記ピストンの位置情報を含む信号を出力する検出装置と、
前記信号に基づいて前記ピストンの位置を取得する位置取得装置と
を有するエンジンシステム。 - 前記検出装置は、少なくとも一部が、前記ピストンが内部で摺動するシリンダライナに設けられ、前記ピストンの摺動方向における位置を検出するように構成されている請求項1記載のエンジンシステム。
- 前記検出装置は、前記ピストンに設けられた被検出部と、前記シリンダライナに設けられた検出部とを有する請求項2記載のエンジンシステム。
- 前記被検出部は、前記ピストンの摺動面において、周方向に複数設けられる請求項3記載のエンジンシステム。
- 前記検出部は、前記ピストンの摺動方向において、前記シリンダライナの掃気ポートよりも燃焼室から離れた位置に設けられる請求項3または4記載のエンジンシステム。
Priority Applications (4)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| KR1020207014939A KR102383655B1 (ko) | 2017-10-27 | 2018-10-26 | 엔진 시스템 |
| EP18870605.5A EP3702597B1 (en) | 2017-10-27 | 2018-10-26 | Engine system |
| DK18870605.5T DK3702597T3 (da) | 2017-10-27 | 2018-10-26 | Motorsystem |
| CN201880077442.2A CN111386389A (zh) | 2017-10-27 | 2018-10-26 | 发动机系统 |
Applications Claiming Priority (2)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| JP2017-207964 | 2017-10-27 | ||
| JP2017207964A JP7309109B2 (ja) | 2017-10-27 | 2017-10-27 | エンジンシステム |
Publications (1)
| Publication Number | Publication Date |
|---|---|
| WO2019083021A1 true WO2019083021A1 (ja) | 2019-05-02 |
Family
ID=66247942
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| PCT/JP2018/039935 Ceased WO2019083021A1 (ja) | 2017-10-27 | 2018-10-26 | エンジンシステム |
Country Status (6)
| Country | Link |
|---|---|
| EP (1) | EP3702597B1 (ja) |
| JP (1) | JP7309109B2 (ja) |
| KR (1) | KR102383655B1 (ja) |
| CN (1) | CN111386389A (ja) |
| DK (1) | DK3702597T3 (ja) |
| WO (1) | WO2019083021A1 (ja) |
Cited By (1)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN112031941A (zh) * | 2019-06-03 | 2020-12-04 | 温特图尔汽柴油公司 | 运行大型发动机的方法和大型发动机 |
Citations (8)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JPS63164535U (ja) * | 1987-04-16 | 1988-10-26 | ||
| JP2002538364A (ja) * | 1999-02-22 | 2002-11-12 | キャタピラー インコーポレイテッド | ミスファイヤまたは初期始動時に高圧作動液で自由ピストン内燃機関を動作させる方法 |
| JP2003517535A (ja) * | 1999-12-14 | 2003-05-27 | ヨンソン,バース | ピストンエンジン内の上死点位置を決定し且つ調節する方法及び装置 |
| JP2014020375A (ja) | 2012-07-17 | 2014-02-03 | Waertsilae Schweiz Ag | 大型往復ピストン燃焼エンジン、ならびにそのようなエンジンを制御する制御機器および方法 |
| WO2015108178A1 (ja) * | 2014-01-20 | 2015-07-23 | 株式会社Ihi | クロスヘッド型エンジン |
| WO2015108138A1 (ja) * | 2014-01-20 | 2015-07-23 | 株式会社Ihi | クロスヘッド型エンジン |
| WO2015108182A1 (ja) * | 2014-01-20 | 2015-07-23 | 株式会社Ihi | エンジン |
| JP2017207964A (ja) | 2016-05-19 | 2017-11-24 | 本田技研工業株式会社 | 車両制御システム、車両制御方法、および車両制御プログラム |
Family Cites Families (4)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JPS6256607A (ja) * | 1985-09-02 | 1987-03-12 | Smc Corp | 流体圧シリンダにおける位置検出器取付用位置調整装置 |
| JP2005048621A (ja) * | 2003-07-31 | 2005-02-24 | Toyota Motor Corp | 内燃機関の圧縮比算出装置、圧縮比算出方法、内燃機関の制御装置およびその制御方法 |
| CA2672588A1 (en) * | 2006-12-13 | 2008-06-19 | Stoneridge Control Devices, Inc. | Cylinder position sensor and cylinder incorporating the same |
| JP6274191B2 (ja) | 2014-12-03 | 2018-02-07 | 株式会社豊田中央研究所 | フリーピストン式発電機の制御装置 |
-
2017
- 2017-10-27 JP JP2017207964A patent/JP7309109B2/ja active Active
-
2018
- 2018-10-26 EP EP18870605.5A patent/EP3702597B1/en active Active
- 2018-10-26 WO PCT/JP2018/039935 patent/WO2019083021A1/ja not_active Ceased
- 2018-10-26 KR KR1020207014939A patent/KR102383655B1/ko active Active
- 2018-10-26 DK DK18870605.5T patent/DK3702597T3/da active
- 2018-10-26 CN CN201880077442.2A patent/CN111386389A/zh active Pending
Patent Citations (8)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JPS63164535U (ja) * | 1987-04-16 | 1988-10-26 | ||
| JP2002538364A (ja) * | 1999-02-22 | 2002-11-12 | キャタピラー インコーポレイテッド | ミスファイヤまたは初期始動時に高圧作動液で自由ピストン内燃機関を動作させる方法 |
| JP2003517535A (ja) * | 1999-12-14 | 2003-05-27 | ヨンソン,バース | ピストンエンジン内の上死点位置を決定し且つ調節する方法及び装置 |
| JP2014020375A (ja) | 2012-07-17 | 2014-02-03 | Waertsilae Schweiz Ag | 大型往復ピストン燃焼エンジン、ならびにそのようなエンジンを制御する制御機器および方法 |
| WO2015108178A1 (ja) * | 2014-01-20 | 2015-07-23 | 株式会社Ihi | クロスヘッド型エンジン |
| WO2015108138A1 (ja) * | 2014-01-20 | 2015-07-23 | 株式会社Ihi | クロスヘッド型エンジン |
| WO2015108182A1 (ja) * | 2014-01-20 | 2015-07-23 | 株式会社Ihi | エンジン |
| JP2017207964A (ja) | 2016-05-19 | 2017-11-24 | 本田技研工業株式会社 | 車両制御システム、車両制御方法、および車両制御プログラム |
Non-Patent Citations (1)
| Title |
|---|
| See also references of EP3702597A4 |
Cited By (7)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN112031941A (zh) * | 2019-06-03 | 2020-12-04 | 温特图尔汽柴油公司 | 运行大型发动机的方法和大型发动机 |
| EP3748144A1 (de) * | 2019-06-03 | 2020-12-09 | Winterthur Gas & Diesel AG | Verfahren zum betreiben eines grossmotors sowie grossmotor |
| JP2020197215A (ja) * | 2019-06-03 | 2020-12-10 | ヴィンタートゥール ガス アンド ディーゼル アーゲー | 大型エンジンの動作方法及び大型エンジン |
| KR20200139626A (ko) * | 2019-06-03 | 2020-12-14 | 빈터투르 가스 앤 디젤 아게 | 대형 엔진을 작동시키기 위한 방법 및 대형 엔진 |
| KR102734506B1 (ko) * | 2019-06-03 | 2024-11-26 | 윈지디 엘티디 | 대형 엔진을 작동시키기 위한 방법 및 대형 엔진 |
| JP7609572B2 (ja) | 2019-06-03 | 2025-01-07 | ヴィンゲーデー リミテッド | 大型エンジンの動作方法及び大型エンジン |
| JP2025041744A (ja) * | 2019-06-03 | 2025-03-26 | ヴィンゲーデー リミテッド | 大型エンジンの動作方法及び大型エンジン |
Also Published As
| Publication number | Publication date |
|---|---|
| JP2019078250A (ja) | 2019-05-23 |
| EP3702597B1 (en) | 2023-04-26 |
| KR20200076718A (ko) | 2020-06-29 |
| EP3702597A1 (en) | 2020-09-02 |
| DK3702597T3 (da) | 2023-05-22 |
| CN111386389A (zh) | 2020-07-07 |
| EP3702597A4 (en) | 2021-08-11 |
| KR102383655B1 (ko) | 2022-04-08 |
| JP7309109B2 (ja) | 2023-07-18 |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| KR101799956B1 (ko) | 엔진 | |
| KR102240874B1 (ko) | 가변 압축 장치 및 엔진 시스템 | |
| KR102383655B1 (ko) | 엔진 시스템 | |
| KR102502627B1 (ko) | 엔진 시스템 | |
| WO2019124431A1 (ja) | 圧縮端圧力制御装置及びエンジンシステム | |
| JP6946977B2 (ja) | 可変圧縮装置及びエンジンシステム | |
| KR102274364B1 (ko) | 가변 압축 장치 및 엔진 시스템 | |
| WO2019107549A1 (ja) | エンジンシステム及び可変圧縮装置の制御方法 | |
| JP2019124133A (ja) | エンジン | |
| JP2019120237A (ja) | 圧縮比制御装置及びエンジンシステム | |
| KR102259354B1 (ko) | 가변 압축 장치 및 엔진 시스템 | |
| JP2019019801A (ja) | 可変圧縮装置及びエンジンシステム | |
| JP2019143528A (ja) | 2ストロークエンジン |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| 121 | Ep: the epo has been informed by wipo that ep was designated in this application |
Ref document number: 18870605 Country of ref document: EP Kind code of ref document: A1 |
|
| NENP | Non-entry into the national phase |
Ref country code: DE |
|
| ENP | Entry into the national phase |
Ref document number: 20207014939 Country of ref document: KR Kind code of ref document: A |
|
| ENP | Entry into the national phase |
Ref document number: 2018870605 Country of ref document: EP Effective date: 20200527 |