WO2020137034A1 - Système d'ouverture/fermeture automatique de porte - Google Patents
Système d'ouverture/fermeture automatique de porte Download PDFInfo
- Publication number
- WO2020137034A1 WO2020137034A1 PCT/JP2019/036609 JP2019036609W WO2020137034A1 WO 2020137034 A1 WO2020137034 A1 WO 2020137034A1 JP 2019036609 W JP2019036609 W JP 2019036609W WO 2020137034 A1 WO2020137034 A1 WO 2020137034A1
- Authority
- WO
- WIPO (PCT)
- Prior art keywords
- door
- unit
- door opening
- closing system
- control device
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Ceased
Links
Images




Classifications
-
- E—FIXED CONSTRUCTIONS
- E05—LOCKS; KEYS; WINDOW OR DOOR FITTINGS; SAFES
- E05F—DEVICES FOR MOVING WINGS INTO OPEN OR CLOSED POSITION; CHECKS FOR WINGS; WING FITTINGS NOT OTHERWISE PROVIDED FOR, CONCERNED WITH THE FUNCTIONING OF THE WING
- E05F15/00—Power-operated mechanisms for wings
- E05F15/60—Power-operated mechanisms for wings using electrical actuators
- E05F15/603—Power-operated mechanisms for wings using electrical actuators using rotary electromotors
- E05F15/611—Power-operated mechanisms for wings using electrical actuators using rotary electromotors for swinging wings
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B60—VEHICLES IN GENERAL
- B60J—WINDOWS, WINDSCREENS, NON-FIXED ROOFS, DOORS, OR SIMILAR DEVICES FOR VEHICLES; REMOVABLE EXTERNAL PROTECTIVE COVERINGS SPECIALLY ADAPTED FOR VEHICLES
- B60J5/00—Doors
- B60J5/04—Doors arranged at the vehicle sides
-
- E—FIXED CONSTRUCTIONS
- E05—LOCKS; KEYS; WINDOW OR DOOR FITTINGS; SAFES
- E05B—LOCKS; ACCESSORIES THEREFOR; HANDCUFFS
- E05B81/00—Power-actuated vehicle locks
- E05B81/54—Electrical circuits
- E05B81/64—Monitoring or sensing, e.g. by using switches or sensors
-
- E—FIXED CONSTRUCTIONS
- E05—LOCKS; KEYS; WINDOW OR DOOR FITTINGS; SAFES
- E05F—DEVICES FOR MOVING WINGS INTO OPEN OR CLOSED POSITION; CHECKS FOR WINGS; WING FITTINGS NOT OTHERWISE PROVIDED FOR, CONCERNED WITH THE FUNCTIONING OF THE WING
- E05F15/00—Power-operated mechanisms for wings
- E05F15/40—Safety devices, e.g. detection of obstructions or end positions
- E05F15/42—Detection using safety edges
- E05F15/43—Detection using safety edges responsive to disruption of energy beams, e.g. light or sound
-
- E—FIXED CONSTRUCTIONS
- E05—LOCKS; KEYS; WINDOW OR DOOR FITTINGS; SAFES
- E05F—DEVICES FOR MOVING WINGS INTO OPEN OR CLOSED POSITION; CHECKS FOR WINGS; WING FITTINGS NOT OTHERWISE PROVIDED FOR, CONCERNED WITH THE FUNCTIONING OF THE WING
- E05F15/00—Power-operated mechanisms for wings
- E05F15/60—Power-operated mechanisms for wings using electrical actuators
- E05F15/603—Power-operated mechanisms for wings using electrical actuators using rotary electromotors
- E05F15/611—Power-operated mechanisms for wings using electrical actuators using rotary electromotors for swinging wings
- E05F15/63—Power-operated mechanisms for wings using electrical actuators using rotary electromotors for swinging wings operated by swinging arms
-
- E—FIXED CONSTRUCTIONS
- E05—LOCKS; KEYS; WINDOW OR DOOR FITTINGS; SAFES
- E05F—DEVICES FOR MOVING WINGS INTO OPEN OR CLOSED POSITION; CHECKS FOR WINGS; WING FITTINGS NOT OTHERWISE PROVIDED FOR, CONCERNED WITH THE FUNCTIONING OF THE WING
- E05F15/00—Power-operated mechanisms for wings
- E05F15/60—Power-operated mechanisms for wings using electrical actuators
- E05F15/603—Power-operated mechanisms for wings using electrical actuators using rotary electromotors
- E05F15/632—Power-operated mechanisms for wings using electrical actuators using rotary electromotors for horizontally-sliding wings
- E05F15/655—Power-operated mechanisms for wings using electrical actuators using rotary electromotors for horizontally-sliding wings specially adapted for vehicle wings
-
- E—FIXED CONSTRUCTIONS
- E05—LOCKS; KEYS; WINDOW OR DOOR FITTINGS; SAFES
- E05F—DEVICES FOR MOVING WINGS INTO OPEN OR CLOSED POSITION; CHECKS FOR WINGS; WING FITTINGS NOT OTHERWISE PROVIDED FOR, CONCERNED WITH THE FUNCTIONING OF THE WING
- E05F15/00—Power-operated mechanisms for wings
- E05F15/70—Power-operated mechanisms for wings with automatic actuation
- E05F15/73—Power-operated mechanisms for wings with automatic actuation responsive to movement or presence of persons or objects
-
- E—FIXED CONSTRUCTIONS
- E05—LOCKS; KEYS; WINDOW OR DOOR FITTINGS; SAFES
- E05F—DEVICES FOR MOVING WINGS INTO OPEN OR CLOSED POSITION; CHECKS FOR WINGS; WING FITTINGS NOT OTHERWISE PROVIDED FOR, CONCERNED WITH THE FUNCTIONING OF THE WING
- E05F15/00—Power-operated mechanisms for wings
- E05F15/40—Safety devices, e.g. detection of obstructions or end positions
- E05F15/42—Detection using safety edges
- E05F15/43—Detection using safety edges responsive to disruption of energy beams, e.g. light or sound
- E05F2015/434—Detection using safety edges responsive to disruption of energy beams, e.g. light or sound with cameras or optical sensors
-
- E—FIXED CONSTRUCTIONS
- E05—LOCKS; KEYS; WINDOW OR DOOR FITTINGS; SAFES
- E05F—DEVICES FOR MOVING WINGS INTO OPEN OR CLOSED POSITION; CHECKS FOR WINGS; WING FITTINGS NOT OTHERWISE PROVIDED FOR, CONCERNED WITH THE FUNCTIONING OF THE WING
- E05F15/00—Power-operated mechanisms for wings
- E05F15/40—Safety devices, e.g. detection of obstructions or end positions
- E05F15/42—Detection using safety edges
- E05F2015/483—Detection using safety edges for detection during opening
-
- E—FIXED CONSTRUCTIONS
- E05—LOCKS; KEYS; WINDOW OR DOOR FITTINGS; SAFES
- E05F—DEVICES FOR MOVING WINGS INTO OPEN OR CLOSED POSITION; CHECKS FOR WINGS; WING FITTINGS NOT OTHERWISE PROVIDED FOR, CONCERNED WITH THE FUNCTIONING OF THE WING
- E05F15/00—Power-operated mechanisms for wings
- E05F15/70—Power-operated mechanisms for wings with automatic actuation
- E05F15/73—Power-operated mechanisms for wings with automatic actuation responsive to movement or presence of persons or objects
- E05F2015/767—Power-operated mechanisms for wings with automatic actuation responsive to movement or presence of persons or objects using cameras
-
- E—FIXED CONSTRUCTIONS
- E05—LOCKS; KEYS; WINDOW OR DOOR FITTINGS; SAFES
- E05Y—INDEXING SCHEME ASSOCIATED WITH SUBCLASSES E05D AND E05F, RELATING TO CONSTRUCTION ELEMENTS, ELECTRIC CONTROL, POWER SUPPLY, POWER SIGNAL OR TRANSMISSION, USER INTERFACES, MOUNTING OR COUPLING, DETAILS, ACCESSORIES, AUXILIARY OPERATIONS NOT OTHERWISE PROVIDED FOR, APPLICATION THEREOF
- E05Y2400/00—Electronic control; Electrical power; Power supply; Power or signal transmission; User interfaces
- E05Y2400/10—Electronic control
- E05Y2400/32—Position control, detection or monitoring
-
- E—FIXED CONSTRUCTIONS
- E05—LOCKS; KEYS; WINDOW OR DOOR FITTINGS; SAFES
- E05Y—INDEXING SCHEME ASSOCIATED WITH SUBCLASSES E05D AND E05F, RELATING TO CONSTRUCTION ELEMENTS, ELECTRIC CONTROL, POWER SUPPLY, POWER SIGNAL OR TRANSMISSION, USER INTERFACES, MOUNTING OR COUPLING, DETAILS, ACCESSORIES, AUXILIARY OPERATIONS NOT OTHERWISE PROVIDED FOR, APPLICATION THEREOF
- E05Y2400/00—Electronic control; Electrical power; Power supply; Power or signal transmission; User interfaces
- E05Y2400/10—Electronic control
- E05Y2400/44—Sensors not directly associated with the wing movement
-
- E—FIXED CONSTRUCTIONS
- E05—LOCKS; KEYS; WINDOW OR DOOR FITTINGS; SAFES
- E05Y—INDEXING SCHEME ASSOCIATED WITH SUBCLASSES E05D AND E05F, RELATING TO CONSTRUCTION ELEMENTS, ELECTRIC CONTROL, POWER SUPPLY, POWER SIGNAL OR TRANSMISSION, USER INTERFACES, MOUNTING OR COUPLING, DETAILS, ACCESSORIES, AUXILIARY OPERATIONS NOT OTHERWISE PROVIDED FOR, APPLICATION THEREOF
- E05Y2400/00—Electronic control; Electrical power; Power supply; Power or signal transmission; User interfaces
- E05Y2400/10—Electronic control
- E05Y2400/44—Sensors not directly associated with the wing movement
- E05Y2400/446—Vehicle state sensors, e.g. parked or inclination
-
- E—FIXED CONSTRUCTIONS
- E05—LOCKS; KEYS; WINDOW OR DOOR FITTINGS; SAFES
- E05Y—INDEXING SCHEME ASSOCIATED WITH SUBCLASSES E05D AND E05F, RELATING TO CONSTRUCTION ELEMENTS, ELECTRIC CONTROL, POWER SUPPLY, POWER SIGNAL OR TRANSMISSION, USER INTERFACES, MOUNTING OR COUPLING, DETAILS, ACCESSORIES, AUXILIARY OPERATIONS NOT OTHERWISE PROVIDED FOR, APPLICATION THEREOF
- E05Y2900/00—Application of doors, windows, wings or fittings thereof
- E05Y2900/50—Application of doors, windows, wings or fittings thereof for vehicles
- E05Y2900/53—Type of wing
- E05Y2900/531—Doors
Definitions
- the present invention relates to an automatic door opening/closing system for automatically opening/closing a vehicle door.
- a system is known that automatically opens and closes the vehicle door by driving it with a motor.
- a system that detects an obstacle on the door opening track and stops the door opening. For example, in the system described in Patent Document 1, the distance between the door and the object is measured by an ultrasonic sensor or the like installed in a pillar of the vehicle body, and an obstacle on the door opening track is detected.
- a system that detects a three-dimensional object (obstacle) existing around the vehicle for the purpose of supporting the parking of the vehicle.
- a bird's-eye view image of a vehicle is generated using a plurality of cameras, the bird's-eye view image is divided into regions by edge line segments extracted from the bird's-eye view image, and the road surface type (running road surface) of each region is divided.
- the road surface type running road surface
- Outer road surface, three-dimensional object are discriminated based on a feature amount such as texture.
- the present invention has been made in view of the above circumstances, and an object thereof is to provide an automatic door opening/closing system capable of detecting an obstacle existing on a road surface around a door and preventing an unintentional disembarkation of an occupant. ..
- An automatic door opening/closing system includes an image capturing unit that captures a road surface around a vehicle including the periphery of a door, a door lock unit that locks the door in a closed state, and a drive unit that opens and closes the door. , An operation unit provided on the indoor side of the door for inputting a door opening operation for unlocking the door by the door lock unit and opening the door by the drive unit, and information for an occupant who has operated the operation unit.
- An informing unit for informing and a control device for controlling the door lock unit, the drive unit, and the informing unit, the control device, when the door opening operation is input to the operation unit, Using the captured image acquired by the image capturing unit, a fault existing on the road surface around the door is detected, and when the fault is detected, a notification of fault detection by the notification unit and input to the operation unit are input. At least one of invalidating the door opening operation is performed.
- an automatic door opening/closing system capable of detecting an obstacle existing on a road surface around a door and preventing an accidental disembarkation of an occupant.
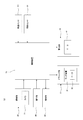
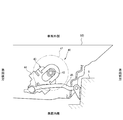
- FIG. 1 is a schematic diagram of an example of a vehicle to which an automatic door opening/closing system is applied for explaining an embodiment of the present invention. It is a functional block diagram of an example of an automatic door opening and closing system for explaining the embodiment of the present invention. It is a schematic diagram of an example of the drive part of FIG. It is a schematic diagram explaining operation
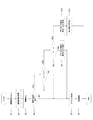
- FIG. 3 is a flowchart of an example of a door opening process performed by the control device of FIG. 2. It is a functional block diagram of the modification of the automatic door opening/closing system of FIG.
- FIG. 1 shows an example of a vehicle to which an automatic door opening/closing system is applied for explaining an embodiment of the present invention
- FIG. 2 shows a functional block of an example of the automatic door opening/closing system.
- the vehicle 1 shown in FIG. 1 is a so-called sedan type vehicle, and the automatic door opening/closing system applied to the vehicle 1 automatically opens and closes the door 2 of the vehicle 1.
- the door 2 includes a door body 3 and a window glass 4 that can be stored in the door body 3.
- the door 2 is connected to the body 6 of the vehicle 1 by a pair of hinges 5 provided at the front end of the door body 3, and is horizontally opened and closed about a hinge shaft 5A of the pair of hinges 5. ..
- the door 2 is a swing door that opens and closes in a horizontal direction, but the door that is automatically opened and closed by the automatic door opening and closing system may be a gull-wing door that opens and closes in the vertical direction or a sliding door. Further, the doors to be automatically opened/closed by the automatic door opening/closing system may be some or all of the driver's seat door, the passenger seat door, and the rear seat door.
- the automatic door opening/closing system 10 applied to the vehicle 1 includes an imaging unit 20, a door lock unit 30, a drive unit 40, an operation unit 50, an alarm unit 60, and a door lock unit 30.
- a controller 70 that controls the drive unit 40 and the notification unit 60 detects a fault existing on the road surface around the door 2 to be automatically opened and closed, and controls the opening and closing of the door 2 according to the detection result.
- the detected obstacle may be an obstacle for an occupant getting off the vehicle, and examples thereof include steps such as curbs and gutters, and locally dissimilar material portions such as manhole covers and tiles that are slippery than asphalt.
- the imaging unit 20 includes one or more cameras 21 using solid-state imaging devices such as a CCD (Charge Coupled Device) image sensor and a CMOS (Complementary metal-oxide-semiconductor) image sensor, and the door 2 to be automatically opened and closed. An image of the road surface around the vehicle 1 including the surrounding area is captured.
- FIG. 1 shows an installation example of the camera 21 when the passenger door is automatically opened and closed. The camera 21 is installed in the door mirror section 7 of the passenger door.
- the number of cameras 21 and the installation locations are appropriately set according to the doors to be automatically opened and closed.
- the rear doors on both sides of the driver's seat and the passenger's side are to be automatically opened or closed, or the driver's door, the passenger's door and the driver's seat are
- the camera 21 may be installed in the door mirror portion 7 of the passenger door and the door mirror portion 7 of the driver door, respectively.
- the driver's door and the assistant are typically used. Cameras are installed at four places on the door mirrors of each seat door.
- the camera installed in the door mirror section for this around view monitor can be suitably used as the camera 21 of the automatic door opening/closing system 10.
- the camera is installed at the same position as the door mirror.
- the camera for the electronic door mirror can be suitably used as the camera 21 of the automatic door opening/closing system 10.
- the installation location of the camera 21 is not limited to the door mirror section 7, and can be appropriately set as long as the road surface around the door 2 to be automatically opened and closed can be imaged.
- the door lock unit 30 includes a striker (not shown) attached to the body 6 of the vehicle 1 and a latch device 31 attached to the door 2.
- the door 2 is held in the closed state by the latch device 31 locking the striker.
- the latch device 31 has a motor 32, and when the motor 32 operates under the control of the control device 70, the latch device 31 releases the striker. As a result, the lock of the door 2 is released and the door 2 can be opened.
- the drive unit 40 includes a motor 41 as a drive source.
- the driving unit 40 drives the door 2 in the door opening direction and the door closing direction.
- the operation unit 50 is provided on the indoor side of the door 2 to be automatically opened and closed, and may be configured by switches such as a touch switch and a push switch. At the time of getting off the vehicle, a door opening operation for unlocking the door by the door lock unit 30 and opening the door by the drive unit 40 is input to the operation unit 50.
- the notification unit 60 is provided in the interior of the vehicle 1 in the vicinity of the door 2 that is the target of the automatic opening/closing, and when the road surface around the door 2 has an obstacle, the occupant who operates the operation unit 50 of the door 2 is provided. That is, the failure detection is notified to the occupant getting off.
- a speaker may be provided on the door 2 to output a sound such as "Please be careful about your feet" from the speaker, or an LED (light emitting diode) may be attached to the lower part of the door 2 inside the room.
- a light emitting element may be provided and the light emitting element may be turned on or blinked.
- the control device 70 is mainly composed of one or more processors, and is configured to include a storage medium such as a ROM (Read Only Memory) and a RAM (Random Access Memory) that holds a control program executed by the processor and a processing result of the processor. Has been done.
- the control device 70 that operates according to the control program detects a fault existing on the road surface around the door 2 that is the target of the automatic opening and closing by using the captured image acquired by the image capturing unit 20, and also according to the detection result.
- the door lock unit 30 and the drive unit 40 are controlled to open and close the door 2.
- the control device 70 is electrically connected to a vehicle speed sensor 80 that detects the vehicle speed of the vehicle 1, and is also electrically connected to an opening degree sensor 81 that detects the opening degree of the door 2.
- the vehicle speed signal output from the vehicle speed sensor 80 and the opening degree signal output from the opening degree sensor 81 are input to the control device 70.
- FIG. 3 shows an example of the drive unit 40.
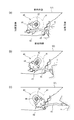
- 4 illustrates the operation of the drive unit 40. (a) shows the case where the door 2 is in the closed state, (b) shows the case where the door 2 is in the half-opened state, and (c) shows the door. 2 shows the case where the door is open.
- the drive unit 40 is arranged at the front end of the door body 3.
- the drive unit 40 includes a motor 41, an output shaft 42, and a link mechanism 43.
- the motor 41 is attached to the inner panel of the door body 3 via an appropriate bracket, and the output shaft 42 is connected to the body 6 via a link mechanism 43.
- the link mechanism 43 has a drive arm 44 and a driven arm 45.
- the drive arm 44 is fixed to the output shaft 42.
- the base end of the driven arm 45 is rotatably connected to the drive arm 44, and the tip of the driven arm 45 is connected to the body 6.
- a clutch mechanism (not shown) may be arranged between the motor 41 and the output shaft 42.
- the clutch mechanism disconnects the power transmission between the motor 41 and the output shaft 42 when the door 2 is manually opened and closed. This makes it easier to open and close the door 2 manually.
- FIG. 5 shows a case where a step due to a curb exists on the road surface
- FIG. 6 shows a case where a step due to a gutter exists on the road surface.
- Steps existing on the road surface can be detected from the image as follows, for example. First, assuming that there is no step on the road surface, the distance between each part of the road surface and the camera 21 shown in the image is determined based on the known installation height of the camera 21 and the position of each part of the road surface in the image. The reference distance D of each part of the road surface is used. By obtaining the distance d between each part of the road surface shown in the image and the camera 21 from the image, the step existing on the road surface can be detected based on the difference between the obtained distance d and the reference distance D, and the height difference ⁇ h can be detected. ..
- the height difference ⁇ h is the distance (absolute value) between the road surface and the top or bottom of the step in the direction perpendicular to the road surface.
- the step due to the curb shown in FIG. 5 is a convex step with respect to the road surface, and the position of the top of the curb with respect to the road surface is + ⁇ h.
- the step due to the gutter shown in FIG. 6 of the road surface is a concave step with respect to the road surface, and the position of the bottom of the gutter with respect to the road surface is ⁇ h.
- the method of obtaining the distance between each part of the road surface shown in the image and the camera 21 from the image is roughly classified into a method using a stereo camera and a method using a monocular camera.
- the distance is obtained from the set of captured images including the parallax acquired by the stereo camera on the principle of triangulation.
- a color filter is used to cause blurring and color shift depending on the distance, and the distance is obtained by analyzing the blurring and color shift of a single acquired image.
- Patent Document 2 As a method of detecting a local dissimilar material portion such as a manhole cover or tile that is slippery compared to asphalt from an image, the method described in Patent Document 2 can be exemplified. That is, by extracting edges from the image, dividing the image into regions by the extracted edges, and discriminating the material of each region from the feature amount such as texture of each region, it is possible to detect a local different material portion.
- FIG. 7 shows an example of the door opening process performed by the control device 70.
- the control device 70 determines whether or not the vehicle 1 has stopped based on the vehicle speed signal input from the vehicle speed sensor 80, starts the door opening process on condition that the vehicle 1 has stopped, and operates the operation unit 50. The input of the door opening operation for is accepted. Then, when the door opening operation is input to the operation unit 50 (step S1), the control device 70 captures an image by the image capturing unit 20 and acquires a captured image of the road surface around the door 2 (step S2).
- control device 70 detects an obstacle existing on the road surface around the door 2 using the acquired captured image (step S3).
- the method of detecting the step as the obstacle and the method of detecting the local different material portion are as described above.
- the door opening process will be described by taking a step as an example.
- step S4 When the obstacle including the step is not detected (NO in step S4), the controller 70 operates the door lock unit 30 to unlock the door 2 (step S5), and operates the drive unit 40 to open the door 2. The door is opened (step S6). Then, the control device 70 sequentially detects the opening degree of the door 2 based on the opening degree signal input from the opening degree sensor 81, and stops the drive unit 40 at the timing when the opening degree of the door 2 reaches the set angle. , The door opening process ends.
- step S7 determines whether the step height difference ⁇ h exceeds the first threshold value h1 (step S7).
- the control device 70 does not regard this step as an obstacle and operates the door lock unit 30 in the same manner as when the step is not detected. Then, the door 2 is unlocked (step S5), and the drive unit 40 is operated to open the door 2 (step S6).
- step S7 when the step height difference ⁇ h exceeds the first threshold value h1 (YES in step S7), the control device 70 determines that the step difference is an obstacle, and the step height difference ⁇ h is larger than the first threshold value h1. It is determined whether or not 2 threshold value h2 is exceeded (step S8).
- the control device 70 determines that the step is a low-risk obstacle, and first notifies the failure detection by the notification unit 60 (Ste S9). After that, the control device 70 operates the door lock unit 30 to unlock the door 2 (step S5), and operates the drive unit 40 to open the door 2 (step S6).
- the fault detection is notified by voice, in step S9, a voice such as "please be careful about your feet" is output to call the attention of the occupant to the road surface around the door 2. As a result, the passenger can be prevented from getting off the vehicle carelessly.
- step S10 determines that the step is a high-risk obstacle and notifies the obstacle detection by the notifying unit 60.
- the door opening operation input to the operation unit 50 is invalidated (step S11), and the door opening process ends.
- a voice such as "Please change the exit location because your feet are dangerous” is output, and the passenger is advised to stop the exit.
- the first threshold value h1 and the second threshold value h2 applied to the step height difference ⁇ h can be set as appropriate, and for example, the first threshold value h1 can be 10 mm and the second threshold value h2 can be 30 mm.
- the control device 70 first notifies the failure detection by the notification unit 60 to alert the occupant to the road surface around the door 2. , The door lock unit 30 is operated to unlock the door 2, and the drive unit 40 is operated to open the door 2. As a result, the passenger can be prevented from getting off the vehicle carelessly.
- FIG. 8 shows functional blocks of a modified example of the automatic door opening/closing system 10.
- the automatic door opening/closing system 10 further includes a rain/snow sensor 82 for detecting rainfall and snowfall, and a distance sensor 83 including a road surface around the door 2 in a measurement range
- the control device 70 includes The rain/snow detection signal output from the rain/snow sensor 82 is input, and the measurement signal output from the distance sensor 83 indicating the distance distribution of the road surface around the door 2 is input.
- the rain/snow sensor 82 is, for example, an optical sensor that detects rain or snow particles passing through the detection area by infrared rays, or detects rain or snow particles attached between the electrodes by conduction between the electrodes. It is an electric sensor.
- the distance sensor 83 is a sensor that measures the distance to an object using, for example, ultrasonic waves, LiDAR (Light Detection and Ranging, Laser Imaging and Detection and Ranging), or millimeter wave radar.
- the control device 70 reduces the first threshold value h1 and the second threshold value h2 applied to the step height difference ⁇ h when the rain and snow detection signal is input. Wet roads are slippery and passengers can easily fall. Therefore, when rain or snow is detected, the fall is prevented by reducing the first threshold value h1 that defines the notification standard for alerting the occupant and the second threshold value h2 that defines the reference for invalidating the door opening operation. it can.
- control device 70 exists on the road surface based on the captured image of the road surface around the door 2 acquired by the imaging unit 20 and the distance distribution of the road surface around the door 2 measured by the distance sensor 83. Detect a step. As a result, it is possible to improve the accuracy of detecting the step and the accuracy of measuring the height difference of the step.
- the door automatic opening/closing system disclosed in the present specification includes an image capturing unit that captures an image of a road surface around a vehicle including the periphery of a door, a door lock unit that locks the door in a closed state, and A drive unit for opening and closing a door, an operation unit provided on the indoor side of the door for inputting a door opening operation for unlocking by the door lock unit and opening the door by the drive unit, and The control unit controls the door lock unit, the drive unit, and the notification unit, and notifies the occupant who has operated the operation unit of the information.
- the captured image acquired by the image capturing unit is used to detect a fault existing on the road surface around the door, and when a fault is detected, the alarm detection unit detects the fault. At least one of notification and invalidation of the door opening operation input to the operation unit is performed.
- the control device uses the captured image to detect a step existing on a road surface around the door, and a height difference exceeds a first threshold value.
- the step is determined as the obstacle, at least one of the notification of the obstacle detection by the notification unit and the invalidation of the unlocking by the door lock unit is performed, and the height difference is less than or equal to the first threshold value.
- the lock by the door lock portion is released.
- the controller detects the obstacle.
- the notification and the invalidation of the door opening operation input to the operation unit are performed, and when a step whose height difference exceeds the first threshold value and is equal to or less than the second threshold value is detected, The alarm is notified by the alarm unit, and thereafter the lock by the door lock unit is released.
- the automatic door opening/closing system disclosed in the present specification includes a sensor that detects rainfall and snowfall, and when the sensor detects rainfall or snowfall, the control device reduces the first threshold value.
- the door automatic opening/closing system disclosed in the present specification includes a rain/snow sensor that detects rainfall and snow, and when the sensor detects rainfall or snow, the control device reduces the second threshold value. To do.
- the door automatic opening/closing system disclosed in the present specification includes a distance sensor including a road surface around the door in a measurement range, and the control device includes the captured image and the door measured by the distance sensor. The step is detected based on the distance distribution of the road surface around the.
- control device detects, as the obstacle, a local dissimilar material portion on a road surface around the door using the captured image.
- the present invention can be used for an automatic door opening/closing system in which a door of a vehicle such as an automobile is driven by a motor to automatically open and close.
Landscapes
- Engineering & Computer Science (AREA)
- Mechanical Engineering (AREA)
- Power-Operated Mechanisms For Wings (AREA)
- Lock And Its Accessories (AREA)
Abstract
La présente invention concerne un système d'ouverture/fermeture automatique de porte comprenant : une unité d'imagerie 20 qui capture une image d'une surface de route autour du véhicule, y compris autour d'une porte 2 ; une unité de verrouillage 30 de porte qui verrouille la porte dans un état fermé ; une unité d'entraînement 40 qui ouvre/ferme la porte 2 ; une unité d'actionnement 50 à laquelle une opération d'ouverture de porte est introduite ; une unité de notification 60 qui informe un occupant ayant actionné l'unité d'actionnement 50 de l'information ; et un dispositif de commande 70. Lorsqu'une opération d'ouverture de porte est introduite dans l'unité d'actionnement 50, le dispositif de commande 70 détecte un obstacle présent sur la surface de la route autour de la porte 2 à l'aide d'une image capturée acquise par l'unité d'imagerie 20. En réponse à la détection d'un obstacle, le dispositif de commande 70 effectue au moins une notification de la détection d'obstacle par l'unité de notification 60 et l'invalidation de l'entrée d'opération d'ouverture de porte à l'unité d'actionnement 50.
Priority Applications (2)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| CN201980079203.5A CN113167096B (zh) | 2018-12-27 | 2019-09-18 | 门自动开闭系统 |
| US17/418,444 US12023998B2 (en) | 2018-12-27 | 2019-09-18 | Automatic door opening and closing system |
Applications Claiming Priority (2)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| JP2018-245650 | 2018-12-27 | ||
| JP2018245650A JP6946605B2 (ja) | 2018-12-27 | 2018-12-27 | ドア自動開閉システム |
Publications (1)
| Publication Number | Publication Date |
|---|---|
| WO2020137034A1 true WO2020137034A1 (fr) | 2020-07-02 |
Family
ID=71129320
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| PCT/JP2019/036609 Ceased WO2020137034A1 (fr) | 2018-12-27 | 2019-09-18 | Système d'ouverture/fermeture automatique de porte |
Country Status (4)
| Country | Link |
|---|---|
| US (1) | US12023998B2 (fr) |
| JP (1) | JP6946605B2 (fr) |
| CN (1) | CN113167096B (fr) |
| WO (1) | WO2020137034A1 (fr) |
Cited By (1)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| EP4379181A4 (fr) * | 2021-11-30 | 2024-12-18 | BYD Company Limited | Procédé de commande et appareil de commande pour l'ouverture d'une portière de véhicule et dispositif de commande de véhicule |
Families Citing this family (10)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JP6946605B2 (ja) * | 2018-12-27 | 2021-10-06 | 三井金属アクト株式会社 | ドア自動開閉システム |
| US11193312B1 (en) * | 2019-09-30 | 2021-12-07 | Ambarella International Lp | Child safety lock |
| JP7654992B2 (ja) * | 2021-02-12 | 2025-04-02 | 株式会社アイシン | 障害物検出装置、方法及びプログラム |
| KR20220138605A (ko) * | 2021-04-06 | 2022-10-13 | 현대자동차주식회사 | 차량용 도어 개폐 제어 시스템 및 방법 |
| US11884238B2 (en) * | 2021-10-21 | 2024-01-30 | Zoox, Inc. | Vehicle door interface interactions |
| US20240401392A1 (en) * | 2021-11-02 | 2024-12-05 | Aisin Corporation | Vehicle door apparatus |
| GB2632758A (en) * | 2022-04-04 | 2025-02-19 | Mobileye Vision Technologies Ltd | Detecting an open door using a sparse representation |
| CN117988661A (zh) * | 2022-10-31 | 2024-05-07 | 长城汽车股份有限公司 | 车辆电动门的控制方法、车辆及存储介质 |
| CN120425964A (zh) * | 2024-02-05 | 2025-08-05 | 麦格纳覆盖件有限公司 | 动力闭合构件系统、对其进行控制的方法以及对其控制系统进行配置的方法 |
| CN118288900B (zh) * | 2024-05-07 | 2026-01-02 | 奇瑞新能源汽车股份有限公司 | 一种汽车开门提醒的方法及系统 |
Citations (5)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JP2008158958A (ja) * | 2006-12-26 | 2008-07-10 | Nissan Motor Co Ltd | 路面判別方法および路面判別装置。 |
| JP2010133901A (ja) * | 2008-12-08 | 2010-06-17 | Denso Corp | 注意喚起装置 |
| JP2017081422A (ja) * | 2015-10-28 | 2017-05-18 | 本田技研工業株式会社 | 車載機器制御システム |
| US20170185821A1 (en) * | 2015-11-16 | 2017-06-29 | MorphoTrak, LLC | Derived virtual quality parameters for fingerprint matching |
| JP2018009386A (ja) * | 2016-07-14 | 2018-01-18 | 三井金属アクト株式会社 | 開閉システム |
Family Cites Families (25)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| US7167796B2 (en) * | 2000-03-09 | 2007-01-23 | Donnelly Corporation | Vehicle navigation system for use with a telematics system |
| EP1619342B1 (fr) * | 2004-07-22 | 2009-04-29 | Bea S.A. | Dispositif thermo-sensible de détection de présence autour de portes automatiques |
| US7761209B2 (en) | 2007-05-21 | 2010-07-20 | Gm Global Technology Operations, Inc. | Obstruction detection device for vehicle door and method |
| JP5359361B2 (ja) * | 2008-09-25 | 2013-12-04 | 株式会社デンソー | 車両ドア開度制御装置 |
| JP2013093013A (ja) * | 2011-10-06 | 2013-05-16 | Ricoh Co Ltd | 画像処理装置、車両 |
| DE102013101639A1 (de) * | 2013-02-19 | 2014-09-04 | Continental Teves Ag & Co. Ohg | Verfahren und Vorrichtung zur Bestimmung eines Fahrbahnzustands |
| DE102014018189A1 (de) * | 2014-12-09 | 2016-06-09 | Daimler Ag | Verfahren und Vorrichtung zum Betrieb eines Fahrzeugs |
| US20160312517A1 (en) * | 2015-04-22 | 2016-10-27 | Ford Global Technologies, Llc | Vehicle and method of opening and closing a door of the vehicle |
| WO2016174753A1 (fr) * | 2015-04-28 | 2016-11-03 | 三井金属アクト株式会社 | Dispositif de verrouillage de porte d'automobile |
| KR20180048916A (ko) * | 2015-09-03 | 2018-05-10 | 패러데이&퓨쳐 인크. | 차량 도어 개폐를 위한 시스템 및 방법 |
| US10829978B2 (en) * | 2015-12-01 | 2020-11-10 | Faraday & Future Inc. | System and method for operating vehicle door |
| US10776636B2 (en) * | 2015-12-29 | 2020-09-15 | Faraday&Future Inc. | Stereo camera-based detection of objects proximate to a vehicle |
| US10407968B2 (en) * | 2016-01-29 | 2019-09-10 | Faraday & Future Inc. | System and method for operating vehicle door |
| US9869119B2 (en) * | 2016-02-29 | 2018-01-16 | Faraday&Future Inc. | Systems and methods for operating vehicle doors |
| JP6583688B2 (ja) * | 2016-05-27 | 2019-10-02 | 三井金属アクト株式会社 | 画像情報認証システム |
| CN107839594B (zh) * | 2016-09-21 | 2020-10-13 | 奥迪股份公司 | 用于车辆的障碍检测装置和方法 |
| CN206797258U (zh) * | 2017-05-22 | 2017-12-26 | 安徽江淮汽车集团股份有限公司 | 智能车门控制系统 |
| US10331134B2 (en) * | 2017-07-14 | 2019-06-25 | Uber Technologies, Inc. | Supervised movement of autonomous vehicle |
| KR102058050B1 (ko) * | 2017-08-16 | 2019-12-20 | 엘지전자 주식회사 | 운행 보조 시스템 및 차량 |
| DE102017216115A1 (de) * | 2017-09-12 | 2019-03-14 | Brose Fahrzeugteile Gmbh & Co. Kommanditgesellschaft, Bamberg | Verfahren zur Verstellung einer Seitentür eines Kraftfahrzeugs und zugehöriger Einklemmschutzsensor |
| US10780821B2 (en) * | 2018-01-09 | 2020-09-22 | Toyota Research Institute, Inc. | System for alerting a vehicle occupant to a ground surface condition adjacent a vehicle door |
| US10876341B2 (en) * | 2018-07-24 | 2020-12-29 | Brose Fahrzeugteile Gmbh & Co. Kommanditgesellschaft, Bamberg | Door drive system |
| JP6869934B2 (ja) * | 2018-11-01 | 2021-05-12 | 三井金属アクト株式会社 | ドア自動開閉システム |
| JP6946605B2 (ja) * | 2018-12-27 | 2021-10-06 | 三井金属アクト株式会社 | ドア自動開閉システム |
| US11708714B2 (en) * | 2021-08-05 | 2023-07-25 | Ford Global Technologies, Llc | Vehicle having door with obstacle avoidance |
-
2018
- 2018-12-27 JP JP2018245650A patent/JP6946605B2/ja active Active
-
2019
- 2019-09-18 CN CN201980079203.5A patent/CN113167096B/zh active Active
- 2019-09-18 US US17/418,444 patent/US12023998B2/en active Active
- 2019-09-18 WO PCT/JP2019/036609 patent/WO2020137034A1/fr not_active Ceased
Patent Citations (5)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JP2008158958A (ja) * | 2006-12-26 | 2008-07-10 | Nissan Motor Co Ltd | 路面判別方法および路面判別装置。 |
| JP2010133901A (ja) * | 2008-12-08 | 2010-06-17 | Denso Corp | 注意喚起装置 |
| JP2017081422A (ja) * | 2015-10-28 | 2017-05-18 | 本田技研工業株式会社 | 車載機器制御システム |
| US20170185821A1 (en) * | 2015-11-16 | 2017-06-29 | MorphoTrak, LLC | Derived virtual quality parameters for fingerprint matching |
| JP2018009386A (ja) * | 2016-07-14 | 2018-01-18 | 三井金属アクト株式会社 | 開閉システム |
Cited By (1)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| EP4379181A4 (fr) * | 2021-11-30 | 2024-12-18 | BYD Company Limited | Procédé de commande et appareil de commande pour l'ouverture d'une portière de véhicule et dispositif de commande de véhicule |
Also Published As
| Publication number | Publication date |
|---|---|
| CN113167096B (zh) | 2022-12-09 |
| US12023998B2 (en) | 2024-07-02 |
| US20220089003A1 (en) | 2022-03-24 |
| CN113167096A (zh) | 2021-07-23 |
| JP2020105812A (ja) | 2020-07-09 |
| JP6946605B2 (ja) | 2021-10-06 |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| JP6946605B2 (ja) | ドア自動開閉システム | |
| CN110300673B (zh) | 车辆外围监视装置 | |
| CN105799578B (zh) | 用于具有滑动门的机动车辆的出口警告系统 | |
| CN107128282B (zh) | 电动车门的移动装置控制 | |
| US20090000196A1 (en) | Systems and methods for preventing motor vehicle doors from coming into contact with obstacles | |
| KR102128048B1 (ko) | 어라운드 뷰 모니터링을 이용한 차량용 웰컴 시스템과 그 동작 방법 | |
| US11057568B2 (en) | Deployable side shark fin with integrated side view camera and sensing device | |
| CN1478171A (zh) | 摄像机监控的运动安全系统 | |
| CN110249105A (zh) | 自动门传感器、自动门系统以及自动门系统的控制方法 | |
| JP2018009386A (ja) | 開閉システム | |
| CN110596780A (zh) | 监控设备 | |
| CN116136145A (zh) | 用于具有前侧向车门和后侧向车门的机动车辆的非接触式障碍物检测的方法和系统 | |
| CN120135088A (zh) | 基于多模态大模型的驻车智能守护方法和系统 | |
| JP2005068640A (ja) | 駐車場の管理方法およびその装置 | |
| JP2004136871A (ja) | 多機能光学検知を備えた自動車 | |
| KR101686772B1 (ko) | 주차장용 차량 외관 상태 정보 획득시스템 | |
| JP6999761B2 (ja) | 車両用周辺監視装置 | |
| JP2004068515A (ja) | 開閉装置の物体検出システム | |
| CN114488332A (zh) | 一种车辆启动阶段的安全检测装置及方法 | |
| JP2020112002A (ja) | ドア自動開閉システム | |
| CN108358026A (zh) | 一种用于门开与关的安全控制装置及采用该装置的电梯 | |
| JP6948752B2 (ja) | 車両用スライドドアの制御装置 | |
| CN223224281U (zh) | 一种行车记录仪 | |
| JPH10208198A (ja) | 車両位置検出装置 | |
| JP3925395B2 (ja) | 車両盗難防止装置及び車両盗難防止システム |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| 121 | Ep: the epo has been informed by wipo that ep was designated in this application |
Ref document number: 19902939 Country of ref document: EP Kind code of ref document: A1 |
|
| NENP | Non-entry into the national phase |
Ref country code: DE |
|
| 122 | Ep: pct application non-entry in european phase |
Ref document number: 19902939 Country of ref document: EP Kind code of ref document: A1 |