WO2020174865A1 - Variable-focal-length lens system and imaging device - Google Patents
Variable-focal-length lens system and imaging device Download PDFInfo
- Publication number
- WO2020174865A1 WO2020174865A1 PCT/JP2019/050965 JP2019050965W WO2020174865A1 WO 2020174865 A1 WO2020174865 A1 WO 2020174865A1 JP 2019050965 W JP2019050965 W JP 2019050965W WO 2020174865 A1 WO2020174865 A1 WO 2020174865A1
- Authority
- WO
- WIPO (PCT)
- Prior art keywords
- lens
- free
- form surface
- unit
- focal length
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Ceased
Links
Classifications
-
- G—PHYSICS
- G02—OPTICS
- G02B—OPTICAL ELEMENTS, SYSTEMS OR APPARATUS
- G02B15/00—Optical objectives with means for varying the magnification
- G02B15/14—Optical objectives with means for varying the magnification by axial movement of one or more lenses or groups of lenses relative to the image plane for continuously varying the equivalent focal length of the objective
- G02B15/146—Optical objectives with means for varying the magnification by axial movement of one or more lenses or groups of lenses relative to the image plane for continuously varying the equivalent focal length of the objective having more than five groups
- G02B15/1461—Optical objectives with means for varying the magnification by axial movement of one or more lenses or groups of lenses relative to the image plane for continuously varying the equivalent focal length of the objective having more than five groups the first group being positive
-
- G—PHYSICS
- G02—OPTICS
- G02B—OPTICAL ELEMENTS, SYSTEMS OR APPARATUS
- G02B15/00—Optical objectives with means for varying the magnification
- G02B15/14—Optical objectives with means for varying the magnification by axial movement of one or more lenses or groups of lenses relative to the image plane for continuously varying the equivalent focal length of the objective
- G02B15/143—Optical objectives with means for varying the magnification by axial movement of one or more lenses or groups of lenses relative to the image plane for continuously varying the equivalent focal length of the objective having three groups only
- G02B15/1431—Optical objectives with means for varying the magnification by axial movement of one or more lenses or groups of lenses relative to the image plane for continuously varying the equivalent focal length of the objective having three groups only the first group being positive
-
- G—PHYSICS
- G02—OPTICS
- G02B—OPTICAL ELEMENTS, SYSTEMS OR APPARATUS
- G02B13/00—Optical objectives specially designed for the purposes specified below
- G02B13/18—Optical objectives specially designed for the purposes specified below with lenses having one or more non-spherical faces, e.g. for reducing geometrical aberration
-
- G—PHYSICS
- G02—OPTICS
- G02B—OPTICAL ELEMENTS, SYSTEMS OR APPARATUS
- G02B3/00—Simple or compound lenses
- G02B3/02—Simple or compound lenses with non-spherical faces
Definitions
- the present technology relates to a variable focal length lens system used in a digital video camera, a digital still camera, and the like, and an imaging device using such a variable focal length lens system.
- this technology uses a zoom of about 24 to 38 mm (35 mm equivalent), an F number of about 1.8 to 4.0, and a zoom ratio of about 10 to 30 times in the wide-angle end state where the angle of view is widest. Suitable for lenses.
- a subject image formed on an image sensor surface by an image sensor using a photoelectric conversion element such as CCD (Charge Coupled Device) or CMOS (Complementary Metal Oxide Semiconductor).
- CCD Charge Coupled Device
- CMOS Complementary Metal Oxide Semiconductor
- a conventional zoom lens has a plurality of movable lens groups, and the movable lens groups are moved in the optical axis direction to change the focal length while keeping the image plane position constant.
- Patent Document 1 For example, see Patent Document 1).
- the zoom lens described in Patent Document 1 includes, in order from the object side to the image side, a first lens group having a positive refractive power, a second lens group having a negative refractive power, and a positive lens group. It is composed of a third lens group having a folding power and a fourth lens group having a positive refractive power.
- the zoom lens when changing the focal length, the first lens group and the third lens group are fixed, the second lens group moves in the optical axis direction, ⁇ 02020/174865 2 (:170?2019/050965
- the fourth lens group moves in the optical axis direction so as to compensate for the accompanying change in the image plane position.
- a sliding variable focal length lens system in which a free-form surface lens having no rotationally symmetric axis is moved in a direction perpendicular to the optical axis to change the angle of view.
- a free-form surface lens having no rotationally symmetric axis is moved in a direction perpendicular to the optical axis to change the angle of view.
- Patent Document 2 In the variable focal length lens system described in Patent Document 2, four free-form lenses move to perform a zoom operation.
- Patent Document 1 Japanese Patent Laid-Open No. 4_4 3 3 1 1
- Patent Document 2 Japanese Unexamined Patent Application Publication No. 2000-7_44063 Disclosure of Invention
- the conventional zoom lens has a limit in reducing the total lens length.
- variable focal length lens system using the free-form surface lens that has been proposed so far, for example, in the lens system in Patent Document 2, by disposing two free-form surface lenses at two locations, respectively Zooming is performed by separating the compensator part and moving it in different directions.
- an object of the variable focal length lens system and the image pickup apparatus of the present technology is to provide a small-sized and high-magnification variable focal length lens system and an image pickup apparatus.
- variable focal length lens system includes a first lens unit composed of at least one lens group in order from the object side to the image side, and a first free-form lens. ⁇ 02020/174865 3 ⁇ (: 170?2019/050965
- the first lens unit and the third lens unit described above are used.
- the lens unit is composed of lenses that are rotationally symmetric with respect to the optical axis and is arranged on the same optical axis.
- the first free-form surface lens and the second free-form surface lens have the same shape and
- the optical axis of the first lens unit and the third lens unit is the axis, and the axis perpendicular to the axis on the image plane is the vertical axis and the axis on the image plane is the vertical axis.
- the first free-form surface lens and the second free-form surface lens are movable in the vertical axis direction, and the first free-form surface lens and the second free-form surface lens are movable.
- the refractive power of the second lens unit is variable, and the position of the lens changes from the wide-angle end state with the shortest focal length to the telephoto end state with the longest focal length.
- the first free-form surface lens and the second free-form surface lens are moved in the direction of the vertical axis along with the movement of a part of the lens group forming the first lens unit and the third lens unit. It is something that moves.
- the first free-form surface lens and the second free-form surface lens move in opposite directions to change the combined refractive power of the second lens unit, and at the same time, the first free-form surface lens and the second free-form surface lens.
- the aberrations caused by the asymmetrical shape cancel each other out in the two lenses, the first free-form surface lens and the second free-form surface lens.
- ⁇ !_ _ The amount of movement of the second free-form surface lens in the vertical axis direction from the wide-angle end state to the telephoto end state.
- the aperture stop be disposed near the second lens unit and satisfy the following conditional expression (4).
- ⁇ Maximum length along the axis from the aperture stop to the second lens unit%: The focal length of the entire lens system in the wide-angle end state
- the off-axis light flux passes through a position close to the optical axis.
- ⁇ !_ _ The amount of movement of the second free-form surface lens in the vertical axis direction from the wide-angle end state to the telephoto end state.
- the first lens unit has, in order from the object side to the image side, a negative refractive power with the first lens group having a positive refractive power.
- a second lens group which has a second lens group, and when the position state of the lens changes from the wide-angle end state to the telephoto end state, the distance between the first lens group and the second lens group increases, and the second lens group It is desirable that at least the second lens unit moves in the optical axis direction so that the distance between the unit and the second lens unit decreases.
- the zooming effect of the first lens unit is increased and the change in the diameter of the aperture stop due to the change in zoom position is suppressed.
- the third lens unit includes a focusing lens that moves in the optical axis direction according to the subject distance.
- an imaging device includes a variable focal length lens system and an imaging element that converts an optical image formed by the variable focal length lens system into an electrical signal
- the lens system comprises, in order from the object side to the image side, a first lens unit composed of at least one lens group, a second lens unit composed of a first free-form surface lens and a second free-form surface lens, and A third lens unit composed of at least one lens group, ⁇ 02020/174865 6 ⁇ (: 170?2019/050965
- the unit and the third lens unit are composed of lenses that are rotationally symmetric with respect to the optical axis and are arranged on the same optical axis. They are arranged in the same shape and are rotated 180° with respect to the optical axis.
- the first free-form surface lens and the second free-form surface lens are movable in the direction of the lower axis, and the first free-form surface lens is movable along the axis. By moving the second free-form surface lens and the second free-form surface lens in opposite directions, the refracting power of the second lens unit can be changed.
- the first free-form surface lens and the second free-form surface lens and the second lens unit that form part of the third lens unit move. Free-form surface lens moves in the vertical axis direction
- the first free-form surface lens and the second free-form surface lens move in opposite directions, so that the combined refractive power of the second lens unit changes and the first free-form surface becomes Since the lens and the second free-form surface lens are moved in the opposite direction by the same amount, the aberrations caused by the asymmetrical shape cancel each other out by the two lenses, the first free-form surface lens and the second free-form surface lens.
- FIG. 1 Fig. 2 to Fig. 17 show an embodiment of a variable focal length lens system and an image pickup apparatus of the present technology. This diagram shows a refractive power arrangement diagram of the variable focal length lens system. Is.
- FIG. 2 is a diagram showing a lens configuration of a first example.
- FIG. 4 is a distortion diagram of the first example.
- FIG. 5 is a diagram showing a lens configuration of a second example.
- FIG. 6 is a spot diaphragm of the second embodiment. ⁇ 02020/174865 7 ⁇ (: 170?2019/050965
- FIG. 7 is a distortion diagram of the second example.
- FIG. 8 is a diagram showing a lens configuration of a third example.
- FIG. 9 is a spot diaphragm of the third embodiment.
- FIG. 10 is a distortion diagram of the third example.
- FIG. 11 is a block diagram showing an example of an image pickup apparatus.
- FIG. 12 is a diagram schematically showing the overall configuration of an operating room system.
- FIG. 13 is a diagram showing a display example of an operation screen on the centralized operation panel.
- FIG. 14 is a diagram showing an example of a state of surgery to which an operating room system is applied.
- Fig. 15 is a block diagram showing an example of the functional configuration of the camera head and XXII shown in Fig. 14.
- FIG. 16 is a block diagram showing an example of a schematic configuration of a vehicle control system.
- FIG. 17 is an explanatory diagram showing an example of installation positions of the vehicle exterior information detection unit and the imaging unit. MODE FOR CARRYING OUT THE INVENTION
- the varifocal lens system of this technology consists of a first lens unit consisting of at least one lens group, a first free-form surface lens and a second free-form surface lens in order from the object side to the image side. It consists of a two-lens unit and a third lens unit that is composed of at least one lens group.
- the first lens unit and the third lens unit are composed of lenses having a rotationally symmetric shape with respect to the optical axis and are arranged on the same optical axis.
- the first free-form surface lens and the second free-form surface lens have the same shape and are arranged 180° rotated with respect to the optical axis.
- the optical axes of the first lens unit and the third lens unit are used as the axes, and the axis perpendicular to the axis on the image plane is the vertical axis, and on the image plane.
- the first free-form surface lens and the second free-form surface lens can move in the vertical axis direction.
- the first free-form surface lens and the second free-form surface lens move in opposite directions, so that the bending force of the second lens unit is variable.
- the lens position changes from the wide-angle end state with the shortest focal length to the telephoto end state with the longest focal length
- part of the lens groups that make up the first lens unit and the third lens unit moves.
- the first free-form surface lens and the second free-form surface lens move in the axial direction.
- rotationally symmetric lenses such as spherical lenses and aspherical lenses are used, and at least two movable lens groups are configured to move in the optical axis direction.
- one movable lens group moves, and the other lens group moves so as to compensate the change in the image plane position due to the movement.
- variable focal length lens system disclosed in Japanese Patent Application Laid-Open No. 2000_4_063, etc.
- four free-form surface lenses are arranged, and all of them are arranged in a direction perpendicular to the optical axis. It was movable. Then, the two free-form lenses arranged on the object side move in opposite directions to each other, thereby changing the refracting power of the entire lens system, and the resulting change in the image plane position is arranged on the image side.
- the two free-form lenses which are the same, move in opposite directions to compensate.
- the XV axis is defined.
- the optical axes of the first lens unit and the third lens unit, which are composed of rotationally symmetric lenses, are the axes, and the plane perpendicular to the axis on the image plane is the axis and the axis and the axis on the image plane are the axes.
- the axis perpendicular to the axis as the main axis, the three axes intersect at the origin on the image plane.
- the first free-form surface lens and the second free-form surface lens have the same shape and are arranged by rotating 180 degrees about the axis. Then, the combined refracting power of the second lens unit changes as the first free-form surface lens and the second free-form surface lens move in opposite directions. By combining this with a general zoom lens, the total optical length can be shortened while keeping the image plane position constant.
- variable focal length lens system of the present technology increases the degree of freedom for changing the focal length by moving the two free-form surface lenses in directions other than the optical axis direction.
- the shape of the free-form surface becomes smooth, and the shift of the stop position and the eccentricity of the free-form surface (lens on the object side and the image side) It has become possible to prevent performance deterioration due to the surfaces collapsing or moving.
- variable focal length lens system of the present technology has various effects, and can provide a small-sized and high-magnification variable focal length lens system.
- the zooming effect of changing the focal length is caused by the combination of moving the conventional zoom lens and the free-form surface lens.
- variable focal length lens system of the present technology it is desirable that the following conditional expression (1) is satisfied.
- % Focal length of the entire lens system in the wide-angle end state ⁇ 0 2020/174865 10 box (: 170?2019/050965
- Conditional expression (1) is a conditional expression that defines the ratio of the second lens unit to the zoom ratio of the entire lens system.
- conditional expression (1) If the upper limit of conditional expression (1) is exceeded, the chromatic aberration that occurs in the telephoto end state becomes large and the optical performance deteriorates.
- ⁇ !_ _ The amount of movement of the second free-form surface lens in the vertical axis direction from the wide-angle end state to the telephoto end state.
- Conditional expressions (2) and (3) are conditional expressions that regulate the movement amounts of the first free-form surface lens and the second free-form surface lens.
- Condition 1 included in Conditional Expressions (2) and (3) sets the focal length of the entire lens system in the wide-angle end state to the maximum zoom ratio in the telephoto end state and the wide-angle end state. When you do, it means that you are %. J% is the focal length in the wide-angle end state, which is the reference ⁇ 0 2020/174865 1 1 ⁇ (: 170?2019/050965
- conditional expressions (2) and (3) are the movement amounts of the first free-form surface lens and the second free-form surface lens with respect to the zoom ratio. Will be optimized.
- conditional expressions (2) and (3) If the upper limits of conditional expressions (2) and (3) are exceeded, a large movement space in the vertical axis direction is required, and the lens barrel size becomes large.
- conditional expressions (2) and (3) If the lower limits of conditional expressions (2) and (3) are exceeded, the shape will change significantly with a small amount of movement, and a large amount of asymmetric aberration will occur.
- variable focal length lens system satisfies the conditional expressions (2) and (3), the moving space in the vertical axis direction of the first free-form surface lens and the second free-form surface lens can be improved. It is possible to reduce the size of the lens barrel and reduce the size of the lens barrel, and it is possible to suppress the occurrence of asymmetrical aberrations due to the movement of the first free-form surface lens and the second free-form surface lens.
- the aperture stop is arranged near the second lens unit and the following conditional expression (4) is satisfied.
- ⁇ Maximum value along the axis from the aperture stop to the second lens unit%: The focal length of the entire lens system in the wide-angle end state
- the off-axis light beam passes through a position close to the optical axis, and asymmetric off-axis aberrations can be suppressed.
- ⁇ !_ _ The amount of movement of the second free-form surface lens in the vertical axis direction from the wide-angle end state to the telephoto end state.
- variable focal length lens system satisfies the conditional expression (5), the moving amounts of the two free-form surface lenses are reduced, and the optical performance can be improved.
- conditional expression (5) should be 1.
- the first lens unit has, in order from the object side to the image side, the first lens group having positive refractive power and the negative lens power.
- the second lens group and when the lens position state changes from the wide-angle end state to the telephoto end state, the distance between the first lens group and the second lens group increases, and the second lens group and the second lens group It is desirable that at least the second lens unit moves in the optical axis direction so that the distance to the lens unit decreases.
- the third lens unit include a focusing lens that moves in the optical axis direction according to the subject distance.
- the third lens unit includes the focusing lens
- the lens groups in the first lens unit and the second lens unit have a focusing action
- the angle of view depending on the change in the subject distance is increased. It is possible to improve the optical performance by avoiding the change of.
- the aperture stop is arranged on the image side of the second lens unit, but the aperture stop is located on the object side of the second lens unit or the second lens unit. It is also possible to place it between the two free-form lenses that compose it.
- the shape of the free-form surface is represented by an XV polynomial.
- the formula that shows the concrete shape is! ⁇ A conic coefficient (conic constant), 0 3, 0 4, -, when the ⁇ 5 3 coefficients, sag 3 3 9 in the axial direction is in Equation 1 below.
- the first free-form surface lens and the second free-form surface lens are moved in the axial direction, the first free-form surface lens and the second free-form surface lens have a symmetrical shape with respect to the flat plane. is there. Specifically, the odd-numbered terms of X mean zero.
- a mouth-pass filter is arranged on the image side of the lens system to prevent the generation of moire fringes, and an infrared cut filter is arranged according to the spectral sensitivity characteristics of the light receiving element.
- an infrared cut filter is arranged according to the spectral sensitivity characteristics of the light receiving element.
- variable focal length lens system of the present technology and numerical examples in which specific numerical values are applied to the embodiments will be described with reference to the drawings and tables.
- FIG. 1 illustrates a refractive power arrangement of a variable focal length lens system according to each embodiment of the present technology.
- the first lens unit II 1, the second lens unit II 2 and the third lens unit II 3 are arranged in order from the object side to the image side.
- the first lens unit II 1 is composed of the first lens group O 1 having a positive refractive power and the second lens group O 2 having a negative refractive power.
- the second lens unit II 2 is composed of a third lens group 0 3 and a fourth lens group 0 4 which are free-form lenses.
- the third lens unit II 3 is composed of the fifth lens group ⁇ 5, the sixth lens group ⁇ 6, the seventh lens group ⁇ 7, and the eighth lens group ⁇ 8.
- the focal length state changes from the wide-angle end state in which the focal length is the shortest to the telephoto end state in which the focal length is the longest
- the first lens group 0 1 is fixed
- the second lens group 0 2 is along the axis.
- the third lens group ⁇ 3 moves in the minor direction in the vertical axis direction
- the fourth lens group ⁇ 4 moves in the positive direction in the vertical axis direction
- the fifth lens group 0 5 moves in the axial direction.
- the 6th lens group 0 6 moves to the object side
- the 7th lens group 0 7 moves to the object side along the axis
- the 8th lens group ⁇ 8 is fixed. To be done.
- the air distance 0 1 between the first lens group ⁇ 1 and the second lens group ⁇ 2 increases, and the air distance 0 2 between the second lens group ⁇ 2 and the third lens group ⁇ 3 decreases.
- the 4th lens group ⁇ 4 and the 5th lens group ⁇ 5 the air gap port 4 decreases, the 5th lens group ⁇ 5 and the 6th lens group ⁇ 6 the air gap 0 5 changes,
- the air gap 6 between the lens group ⁇ 6 and the 7th lens group ⁇ 7 changed, and the 7th lens group ⁇ 7 and the 8th lens group ⁇ 02020/174865 15 ⁇ (: 170?2019/050965
- the air gap 07 with 08 is increased.
- the aperture stop 3 is arranged on the image side of the fourth lens group 04, and is fixed in the optical axis direction when the focal length changes.
- the image pickup side of the eighth lens group 8 is provided with a rear cover filter, a mouth-pass filter, and a cover glass for an image sensor.
- the aspherical surface is represented by the following mathematical formula.
- 1 to 1 are distances from the optical axis, 2 is sag amount, ⁇ is curvature, 1 ⁇ is conic coefficient (conical constant), 8, and are aspherical coefficients.
- FIG. 2 shows a lens cross-sectional view of a variable focal length lens system 1 according to the first example of the present technology.
- the first lens group ⁇ 1 has a cemented lens !_ 1 1 consisting of a negative meniscus lens having a concave surface facing the image side and a positive lens having a convex surface facing the object side, and a convex surface facing the object side. It consists of a meniscus-shaped positive lens !_ 1 2.
- the second lens group 02 is a meniscus-shaped negative lens whose convex surface faces the object side!
- It consists of 2 1, a cemented lens !_ 2 2 composed of a biconcave lens and a biconvex lens, and a negative lens !_ 2 3 with the concave surface facing the object side.
- the third lens group 0 3 is composed of one first free-form surface lens !_ 3
- the fourth lens group 0 4 is composed of one second free-form surface lens !_ 4.
- Free-form surface lens !_ 3 and 2nd free-form surface lens !_ 4 are arranged with their axes inverted.
- the fifth lens group 0 5 is a cemented lens of a biconvex positive lens !_ 5 1 and a positive lens with a convex surface facing the object side and a negative lens with a concave surface facing the image side !_ 5 2 It consists of and. ⁇ 02020/174865 16 ⁇ (: 170?2019/050965
- 6th lens group ⁇ 6 is a positive biconvex lens! -Composed of 6.
- the seventh lens group ⁇ 7 is composed of a negative lens !_ 7 having a concave surface facing the image side.
- the eighth lens group 08 is composed of a positive lens !_ 8 having a convex surface directed toward the object side.
- the movement amounts of the first free-form surface lens !_ 3 and the second free-form surface lens !_ 4 in the vertical axis direction are slightly different. This makes it possible to reduce the size of the variable focal length lens system 1 in the vertical axis direction.
- Tables 1 to 4 below show values of specifications of the first embodiment of the present technology.
- Table 1 shows the lens data such as the radius of curvature of each lens
- Table 2 shows the variable distance and movement amount (zoom displacement amount) when changing the focal length
- Table 3 shows the free-form lens range.
- the XV free-form surface coefficients (XV polynomial coefficients) that represent the shape, and Table 4 show the aspherical surface coefficients.
- Table 5 shows the corresponding values of the conditional expressions in the first embodiment.
- Fig. 3 shows the spot diagram of the first embodiment in the wide-angle end state and the telephoto end state
- Fig. 4 shows the distortion diagram of the first embodiment.
- FIG. 5 shows a lens cross-sectional view of a variable focal length lens system 2 according to the second example of the present technology.
- the first lens group ⁇ 1 consists of a cemented lens !_ 1 1 consisting of a negative meniscus lens with a concave surface facing the image side and a positive lens with a convex surface facing the object side, and a convex surface facing the object side. It consists of a meniscus-shaped positive lens !_ 1 2.
- the second lens group 0 2 is a negative meniscus lens whose convex surface faces the object side!
- the third lens group 0 3 is composed of one first free-form surface lens !_ 3
- the fourth lens group 0 4 is composed of one second free-form surface lens !_ 4.
- Free-form surface lens !_ 3 and 2nd free-form surface lens !_ 4 are arranged with their axes inverted.
- the fifth lens group 0 5 is a cemented lens which is a biconvex positive lens !_ 5 1 and a positive lens with a convex surface facing the object side and a negative lens with a concave surface facing the image side !_ 5 2 It consists of and.
- 6th lens group ⁇ 6 is a biconvex positive lens! -Composed of 6.
- the seventh lens group ⁇ 7 is composed of a negative lens !_ 7 having a concave surface facing the image side.
- the eighth lens group ⁇ 8 is composed of a positive lens !_ 8 with a convex surface facing the object side.
- the movement amounts of the first free-form surface lens !_ 3 and the second free-form surface lens !_ 4 in the vertical axis direction are slightly different. This makes it possible to reduce the size of the variable focal length lens system 2 in the vertical axis direction.
- Tables 6 to 9 below show values of specifications of the second embodiment of the present technology.
- Table 6 shows lens data such as the radius of curvature of each lens
- Table 7 shows the variable distance and the amount of movement (zoom displacement) when changing the focal length
- Table 8 shows the free-form surface lens.
- the XV free-form surface coefficient (XV polynomial coefficient) that represents the shape and Table 9 show the aspherical surface coefficient.
- Table 10 shows the corresponding values of the conditional expressions in the second embodiment.
- Fig. 6 shows the spot diagram of the second example in the wide-angle end state and the telephoto end state
- Fig. 7 shows the distortion diagram of the second example.
- FIG. 8 shows a lens cross-sectional view of a variable focal length lens system 3 according to the third example of the present technology.
- the first lens group ⁇ 1 has a cemented lens !_ 1 1 consisting of a negative meniscus lens with a concave surface facing the image side and a positive lens with a convex surface facing the object side, and a convex surface facing the object side. It consists of a meniscus-shaped positive lens !_ 1 2.
- the second lens group 0 2 is a negative lens !_ 21 with a concave surface facing the image side, and a cemented lens of a biconcave lens and a biconvex lens! -2 2 and a negative lens with concave surface facing the object side !_ 2 ⁇ 02020/174865 28 ⁇ (: 170?2019/050965
- the third lens group 0 3 is composed of one first free-form surface lens !_ 3
- the fourth lens group 0 4 is composed of one second free-form surface lens !_ 4.
- Free-form surface lens !_ 3 and 2nd free-form surface lens !_ 4 are arranged with their axes inverted.
- the fifth lens group 0 5 is a cemented lens which is a biconvex positive lens !_ 5 1 and a positive lens with a convex surface facing the object side and a negative lens with a concave surface facing the image side !_ 5 2 It consists of and.
- 6th lens group ⁇ 6 is a positive biconvex lens! -Composed of 6.
- the seventh lens group ⁇ 7 is composed of a negative lens !_ 7 having a concave surface facing the image side.
- the eighth lens unit ⁇ 8 is composed of a positive lens !_ 8 having a convex surface facing the image side.
- Tables 11 to 14 below show values of specifications of the third embodiment of the present technology.
- 1 1 shows lens data such as the radius of curvature of each lens
- Table 12 shows the variable interval and movement amount (zoom displacement amount) when changing the focal length
- Table 13 shows the free curved lens
- Table 14 shows aspherical surface coefficients.
- Table 15 shows the corresponding values of the conditional expressions in the third embodiment.
- Fig. 9 shows the spot diagram of the third example in the wide-angle end state and the telephoto end state
- Fig. 10 shows the distortion diagram of the third example.
- the imaging device of the present technology has a variable focal length lens system in which the first lens unit is composed of at least one lens group in order from the object side to the image side, the first free-form surface lens and the second free-form surface lens. It is composed of a second lens unit composed of and a third lens unit composed of at least one lens group.
- variable focal length lens system is configured, and the first lens unit and the third lens unit are composed of lenses that are rotationally symmetric with respect to the optical axis. ⁇ 02020/174865 33 ⁇ (: 170?2019/050965
- first free-form surface lens and the second free-form surface lens have the same shape and are arranged by rotating 180 degrees with respect to the optical axis.
- variable focal length lens system has the optical axes of the first lens unit and the third lens unit as axes, and the axis perpendicular to the axes on the image plane as the lower axis.
- the first free-form surface lens and the second free-form surface lens can move in the direction of the vertical axis, where the vertical axis on the image plane and the axis perpendicular to the axis are the vertical axes.
- variable focal length lens system moves the first free-form surface lens and the second free-form surface lens in opposite directions, so that the refractive power of the second lens unit is increased. It is variable, and when the lens position changes from the wide-angle end state where the focal length is the shortest to the telephoto end state where the focal length is the longest, the lens groups that make up the first lens unit and the third lens unit Along with the partial movement, the first free-form surface lens and the second free-form surface lens move in the axial direction.
- variable focal length lens system includes the first free-form surface lens and the first free-form surface lens.
- Free-form surface lenses are arranged in the same shape, rotated 180 degrees about the axis. Then, the combined refractive power of the second lens unit changes as the first free-form surface lens and the second free-form surface lens move in opposite directions. By combining this with a general zoom lens, the overall optical length can be shortened while keeping the image plane position constant.
- the image pickup device of the present technology uses the two free-form surface lenses of the variable focal length lens system other than the optical axis direction.
- the degree of freedom to change the focal length is increased by moving to.
- the shape of the free-form surface becomes smooth, and the shift of the stop position and the eccentricity of the free-form surface (the lens on the object side and the image side) It has become possible to prevent performance deterioration due to the surfaces collapsing or moving.
- the occurrence of is canceled out by the two lenses, the first free-form surface lens and the second free-form surface lens, and good optical performance is realized.
- the imaging device of the present technology can provide various effects, and can provide a small-sized and high-magnification imaging device.
- FIG. 11 shows a block diagram of a digital still camera according to an embodiment of an imaging device of the present technology.
- the image pickup device (digital still camera) 100 is an image pickup device 10 having a photoelectric conversion function for converting captured light into an electric signal, and a signal for analog-digital conversion of a captured image signal. It has a camera signal processing unit 20 for performing processing and an image processing unit 30 for performing recording/reproducing processing of image signals. Further, the image pickup apparatus 100 writes and reads an image signal to and from a display section 40 that displays a shot image and the like, and a memory 90. (Reader/Writer) 50 and the entire control of the imaging device 100 60, an input unit 70 such as various switches for performing a desired operation by the user, and a lens drive control unit 80 for controlling the drive of the lens group (movable group).
- an input unit 70 such as various switches for performing a desired operation by the user
- a lens drive control unit 80 for controlling the drive of the lens group (movable group).
- the camera signal processing unit 20 performs various kinds of signal processing such as conversion of an output signal from the image sensor 10 into a digital signal, noise removal, image quality correction, and conversion into a luminance/color difference signal.
- the image processing unit 30 performs compression coding/expansion decoding processing of an image signal based on a predetermined image data format, conversion processing of data specifications such as resolution, and the like.
- the display section 40 has a function of displaying various data such as an operation state of the user's input section 70 and a captured image.
- [0158] 0 is a memory for image data encoded by the image processing unit 30.
- the 0 II 60 functions as a control processing unit that controls each circuit block provided in the imaging device 100, and controls each circuit block based on an instruction input signal from the input unit 70. To do. ⁇ 0 2020/174865 35 ⁇ (: 170?2019/050965
- the input section 70 outputs an instruction input signal corresponding to the user's operation to ⁇ II60.
- the lens drive control unit 80 controls a motor or the like (not shown) that drives the lens group based on the control signal from 091 ⁇ 60.
- the memory 90 is, for example, It is a semiconductor memory that can be attached to and detached from the slot connected to 0.
- the memory 90 is not removable from the slot, but may be incorporated inside the image pickup apparatus 100.
- the shot image signal is output to the display unit 40 via the camera signal processing unit 20 and displayed as a camera through image.
- the photographed image signal is output from the camera signal processing unit 20 to the image processing unit 30 and compression-coded, and a predetermined image signal is output. Converted to digital data in data format. The converted data is Output to and written to memory 90.
- Focusing is based on the control signal from II 60.
- imaging refers to photoelectric conversion processing of converting light captured by the imaging element 10 into an electrical signal, and output signal from the imaging element 10 by the camera signal processing unit 20.
- noise removal To digital signals, noise removal, image quality correction, conversion to luminance/color difference signals, and compression/decompression/decoding of image signals based on a predetermined image data format by the image processing unit 30.
- Conversion processing of data specifications such as resolution, A process that includes only part or all of a series of processes up to the process of writing an image signal to the memory 90 by ⁇ 02020/174865 36 ⁇ (: 170?2019/050965
- imaging may refer only to photoelectric conversion processing for converting the light captured by the image sensor 10 into an electrical signal, and the light captured by the image sensor 10 is converted into an electrical signal. You may also refer to the processes from photoelectric conversion processing to conversion to conversion to digital signals of output signals from the image sensor 10 by the camera signal processing unit 20, noise removal, image quality correction, conversion to luminance/color difference signals, etc. , The photoelectric conversion process that converts the light captured by the image sensor 10 into an electrical signal is converted to the digital signal of the output signal from the image sensor 10 by the camera signal processing unit 20, noise removal, image quality correction, and brightness.
- the photoelectric conversion process of converting the captured light by the image sensor 10 into an electric signal may be performed, and the output signal from the image sensor 10 by the camera signal processing unit 20 may be converted into a digital signal, noise removal, Image quality correction, brightness/color difference signal conversion processing, etc.
- image processing unit 30 compression coding/decompression/decoding processing of image signals based on a predetermined image data format and conversion processing of data specifications such as resolution. You may point through It may be up to the process of writing the image signal to the memory 90 by. In the above process, the order of each process may be appropriately changed.
- the imaging device 100 includes the image sensor 10 that performs the above processing, the camera signal processing unit 20 and the image processing unit 30. It may be configured to include only some or all of 50.
- variable focal length lens system of the present technology in addition to the first lens group 0 1 to the eighth lens group 08, other optical elements such as lenses having no refractive power are arranged. May be.
- the lens configuration of the variable focal length lens system of the present technology is substantially the lens configuration of the first lens group 0 1 to the eighth lens group 08. ⁇ 02020/174865 37 ⁇ (: 17 2019/050965
- the above-described imaging device is used as a camera unit of a digital input/output device such as a digital still camera, a digital video camera, a mobile phone with a built-in camera, or a portable terminal such as a tablet with a built-in camera. It can be widely applied.
- a digital input/output device such as a digital still camera, a digital video camera, a mobile phone with a built-in camera, or a portable terminal such as a tablet with a built-in camera. It can be widely applied.
- the technology according to the present disclosure can be applied to various products.
- the technology according to the present disclosure may be applied to an operating room system.
- FIG. 12 is a diagram schematically showing an overall configuration of an operating room system 510 to which the technology according to the present disclosure can be applied.
- the devices installed in the operating room are audiovisual controllers (8/
- Fig. 12 shows a group of various devices for endoscopic surgery 5 101, a ceiling camera 5 1 8 7 installed on the ceiling of the operating room to image the operator's hand, and an operating room.
- An operating room camera 518 9 installed on the ceiling of the operating room to capture an image of the entire operating room, multiple display devices 5 1 0 3 8 to 5 1 0 3 0, a recorder 5 1 0 5 and a patient bed. 5 1 8 3 and lights 5 1 9 1 are shown.
- the device group 5101 belongs to an endoscopic surgery system 5113 described later, and is imaged by the endoscope or the endoscope. It is composed of a display device for displaying an image. Each device belonging to the endoscopic surgery system 5 1 1 3 is also called a medical device. On the other hand, the display devices 5103 to 5103, the recorder 5105, the patient bed 5183 and the illumination 5191 are separated from the endoscopic surgery system 5113. For example, a device installed in an operating room. Each device that does not belong to these endoscopic surgery systems 5 1 1 3 is also called a non-medical device. The audiovisual controller 510 and/or the operating room control device 510 control the operations of these medical devices and non-medical devices in cooperation with each other. ⁇ 02020/174865 38 ⁇ (: 170?2019/050965
- the audiovisual controller 5107 centrally controls the processing related to image display in medical devices and non-medical devices.
- the device group 5101, the ceiling camera 5187 and the operating room camera 518 have information to be displayed during surgery (hereinafter , which is also referred to as display information) (hereinafter, also referred to as a sender's device).
- the display devices 5103 to 5130 may be devices to which display information is output (hereinafter, also referred to as output destination devices).
- the recorder 510 may be a device that corresponds to both the source device and the output destination device.
- the audiovisual controller 5107 controls the operations of the transmission source device and the output destination device, acquires display information from the transmission source device, and transmits the display information to the output destination device for display or It has a recording function.
- the display information includes various images taken during the operation, various information related to the surgery (for example, the patient's physical information, past examination results, information about the surgical procedure, etc.).
- the audiovisual controller 5107 has information about the image of the surgical site in the body cavity of the patient, which is imaged by the endoscope, as display information from the device group 5101. Can be sent. Further, the ceiling camera 5187 can transmit, as the display information, information about the image of the operator's hand imaged by the ceiling camera 5187. Further, the operating room camera 5189 can transmit, as the display information, information about an image showing the state of the entire operating room imaged by the operating room camera 5189. If another device having an imaging function is present in the operating room system 510, the audiovisual controller 5107 is also displayed by the other device as the display information. Information about the image may be obtained.
- the recorder 5105 information about these images captured in the past is recorded by the audiovisual controller 5107.
- the audiovisual controller 5107 can acquire, as the display information, information about the image captured in the past from the recorder 5105. It should be noted that the recorder 510 may also record various information regarding surgery in advance. Yes.
- the audiovisual controller 5107 is a display device which is an output destination device.
- the display device 5 103 A is a display device that is installed by being suspended from the ceiling of the operating room
- the display device 5 103 B is a display device that is installed on the wall of the operating room
- the display device 5103C is a display device installed on a desk in the operating room
- the display device 5103D is a mobile device having a display function (for example, a tablet PC (Persona I Computer)). ..
- the operating room system 510 may include a device outside the operating room.
- the device outside the operating room may be, for example, a server connected to a network built inside or outside the hospital, a PC used by medical staff, or a projector installed in a conference room of a hospital.
- the audiovisual controller 5107 may display the display information on the display device of another hospital via a video conference system or the like for remote medical treatment. it can.
- the operating room control device 510 centrally controls processing other than processing related to image display in non-medical devices.
- the operating room controller 5109 controls the drive of the patient bed 5183, the ceiling camera 518, the operating room camera 518 and the lighting 511.
- the operating room system 510 is provided with a centralized operation panel 5 1 1 1, and the user uses the centralized operation panel 5 1 1 1 to connect to the audiovisual controller 5 1 0 7. It is possible to give an instruction for displaying an image and give an instruction for the operation of the non-medical device to the operating room control device 510.
- the centralized operation panel 5 1 1 1 1 is configured by providing a touch panel on the display surface of the display device.
- Fig. 13 is a diagram showing a display example of an operation screen on the centralized operation panel 5 1 1 1.
- the operating room system 510 is connected to the output device. Shows the operation screen corresponding to the case where two display devices are provided.
- the operation screen 5 1 9 3 is provided with a source selection area 5 1 9 5, a preview area 5 1 9 7 and a control area 5 2 0 1.
- the sender device provided in the operating room system 510 and the thumbnail screen showing the display information of the sender device are displayed in association with each other. It The user can select the display information to be displayed on the display device from any of the transmission source devices displayed in the transmission source selection area 5 195.
- the preview area 5197 a preview of the screen displayed on the two display devices (Monit or U Monitor) that are the output destination devices is displayed.
- four images are displayed in P in P on one display device.
- the four images correspond to the display information transmitted from the transmission source device selected in the transmission source selection area 5195.
- one is displayed relatively large as the main image and the remaining three are displayed relatively small as sub-images.
- the user can switch the main image and the sub image by appropriately selecting the area in which the four images are displayed.
- a status display area 519 9 is provided below the area where the four images are displayed, and the status related to the operation (for example, the elapsed time of the operation, the physical information of the patient, etc.) is provided in the area. ) Can be displayed as appropriate.
- the control area 5201 is a source operation area 5203 that displays GUI (Graphical User Interface) parts for operating the source device and the output destination.
- An output destination operation area 5205 for displaying GU parts for operating the device is provided.
- the sender operation area 5203 is equipped with GU parts for performing various operations (pan, tilt, and zoom) on the camera of the sender device having an imaging function. It has been done. The user can operate the operation of the camera in the transmission source device by appropriately selecting these GU parts. The illustration is omitted. ⁇ 02020/174865 41 ⁇ (: 170?2019/050965
- the sender operation area 520 3 may be provided with a part for performing operations such as reproduction, stop reproduction, rewind, and fast forward of the image.
- the operation screen displayed on the centralized operation panel 5 1 1 1 is not limited to the example shown in the figure, and the user can prepare for the operating room system 5 1 0 0 via the centralized operation panel 5 1 1 1. It may be possible to input an operation to each device that can be controlled by the audiovisual controller 5107 and the operating room control device 5109.
- Fig. 14 is a diagram showing an example of a state of surgery to which the operating room system described above is applied.
- the ceiling camera 5 1 8 7 and the operating room camera 5 1 8 9 are provided on the ceiling of the operating room and are used by a surgeon (doctor) who performs treatment on the affected area of the patient 5 1 8 5 on the patient bed 5 1 8 3. ) It is possible to take a picture of the condition of the hand and the entire operating room.
- the ceiling camera 518 and the operating room camera 518 may be provided with a magnification adjusting function, a focal length adjusting function, a photographing direction adjusting function, and the like.
- the lighting 5 1 9 1 is installed on the ceiling of the operating room and illuminates at least the hand of the operator 5 1 8 1.
- the illumination 519 1 may be capable of appropriately adjusting the amount of irradiation light, the wavelength (color) of irradiation light, the irradiation direction of light, and the like.
- Endoscopic surgery system 5 1 1 3, patient bed 5 1 8 3, ceiling camera 5
- the visual field auditory controller 5107 and the operating room controller 5109 are connected so that they can cooperate with each other.
- a centralized operation panel 5 1 1 1 1 is provided in the operating room. ⁇ 02020/174865 42 ⁇ (: 170?2019/050965
- the endoscopic surgery system 5 1 1 3 includes an endoscope 5 1 1 5 and other surgical tools 5 1 3 1 and a support arm device 5 1 that supports the endoscope 5 1 1 5. 4 1 and a force unit 5 1 5 1 equipped with various devices for endoscopic surgery.
- a plurality of tubular openers called 5 1 39 are punctured in the abdominal wall. Then, the lens barrel 5 1 1 3 of the endoscope 5 1 1 5 and other surgical tools 5 1 3 1 are inserted into the body cavity of the patient 5 1 8 5 from the rocker lockers 5 1 39 3 to 5 1 39. It In the example shown in the figure, a pneumoperitoneum tube 5 133, an energy treatment tool 5 1 35 and forceps 5 1 37 are inserted into the body cavity of the patient 5 1 85 as other surgical tools 5 1 3 1. Further, the energy treatment tool 51-35 is a treatment tool for performing incision and separation of tissue, sealing of blood vessels, and the like by high-frequency current or ultrasonic vibration. However, the illustrated technique *5 1 3 1 is only an example, and various types of surgical instruments commonly used in endoscopic surgery such as a concussion and a retractor are used as the surgical instrument 5 13 1. You can
- An image of the surgical site in the body cavity of the patient 5 1 85 taken by the endoscope 5 1 1 5 is displayed on the display device 5 1 55.
- the surgeon 5 1 81 uses the energy treatment tool 5 1 35 and forceps 5 1 37 while watching the image of the surgical site displayed on the display device 5 1 55 in real time, for example, to perform treatment such as excision of the affected area. I do.
- the pneumoperitoneum tube 5 1 33, the energy treatment tool 5 1 35, and the forceps 5 1 37 are supported by the operator 5 18 1 or an assistant or the like during the operation.
- the support arm device 5 1 4 1 includes an arm portion 5 1 45 extending from the base portion 5 1 43.
- the arm portion 5 1 45 is the joint portion 5 1 473, It is composed of 5 1 4 7 b, 5 1 4 7 c, and links 5 1 4 9 a and 5 1 4 9 b, and is driven by the control from the arm controller 5 1 5 9.
- the endoscope 5 1 1 5 is supported by the arm 5 1 4 5 and its position and posture are controlled. As a result, stable fixation of the endoscope 5115 can be realized.
- the endoscope 5 1 15 is connected to the lens barrel 5 1 1 7 where a region of a predetermined length from the distal end is inserted into the body cavity of the patient 5 1 8 5 and the proximal end of the lens barrel 5 1 1 7. It is composed of the camera head 5 1 1 9 and.
- the endoscope 5 1 15 that is configured as a so-called rigid endoscope having a rigid lens barrel 5 1 17 is shown, but the endoscope 5 1 15 is a flexible mirror. It may be configured as a so-called flexible mirror having a cylinder 5 117.
- An opening in which an objective lens is fitted is provided at the tip of the lens barrel 5 1 1 7.
- a light source device 5 1 5 7 is connected to the endoscope 5 1 15 and light generated by the light source device 5 1 5 7 is extended to the inside of the lens barrel 5 1 1 7.
- the light is guided to the tip of the lens barrel by the guide, and is irradiated toward the observation target in the body cavity of the patient 518 through the objective lens.
- the endoscope 5115 may be a direct-viewing endoscope, or a perspective or side-viewing endoscope.
- An optical system and an image pickup device are provided inside the camera head 511 and the reflected light (observation light) from the observation target is focused on the image pickup device by the optical system.
- the observation light is photoelectrically converted by the imaging device, and an electric signal corresponding to the observation light, that is, an image signal corresponding to the observation image is generated.
- the image signal is sent to the camera control unit (CCU: Camera Control Unit) 5 1 5 3 as R A W data.
- the camera head 511 is equipped with a function to adjust the magnification and focal length by appropriately driving the optical system.
- the camera head 5 1 to support stereoscopic viewing (3D display), etc., the camera head 5 1
- a plurality of image pickup devices may be provided in 19.
- the relay light is introduced inside the lens barrel 5 1 1 1 7 in order to guide the observation light to each of the plurality of image pickup elements.
- the CCU 515 is composed of a CPU (Central Processing Unit), a GPU (Graphics Processing Unit), and the like, and integrally controls the operations of the endoscope 5115 and the display device 515.
- the CCU 5 1 53 displays an image based on the image signal, such as development processing (demosaic processing), on the image signal received from the camera head 5 1 19.
- image processing such as development processing (demosaic processing)
- the CCU 5 1 53 provides the image signal subjected to the image processing to the display device 5 1 55.
- the audiovisual controller 5107 shown in FIG. 12 is connected to the ⁇ 115115.
- the CCU 5 1 53 also provides the image signal subjected to the image processing to the audiovisual controller 5 107.
- the CCU 5 1 53 also sends a control signal to the camera head 5 1 19 to control its drive.
- the control signal may include information regarding imaging conditions such as magnification and focal length.
- the information regarding the imaging condition may be input via the input device 5 1 61 or the above-described centralized operation panel 5 1 1 1.
- the display device 5 1 55 is controlled by the CC U 5 1 53, and the CCU 5 1 5
- the endoscope 5 1 1 5 is compatible with high-resolution shooting such as 4 K (horizontal pixel number 3840 x vertical pixel number 2 1 60) or 8 K (horizontal pixel number 7680 x vertical pixel number 4320).
- the display device 5 1 55 is capable of high-resolution display and/or 3D display. Can be used. If the device is compatible with high-resolution shooting such as 4 K or 8 K, a more immersive feeling can be obtained by using a display device 5 1 55 having a size of 55 inches or more. Further, a plurality of display devices 5 1 55 having different resolutions and sizes may be provided depending on the application.
- the light source device 5 1 57 is composed of a light source such as an LED (Ught emitting diode), and supplies the endoscope 5 1 15 with irradiation light for photographing the operation part.
- the arm control device 5 1 5 9 is composed of, for example, a processor such as a CPU, and operates according to a predetermined program, so that the arm portion 5 1 of the support arm device 5 1 4 1 follows a predetermined control method. Control the drive of 4 5.
- the input device 5 16 1 is an input interface to the endoscopic surgery system 5 1 13.
- the user can input various information and instructions to the endoscopic surgery system 5 1 1 3 via the input device 5 16 1.
- the user inputs various kinds of information related to the surgery, such as the physical information of the patient and the information about the surgical procedure through the input device 5 16 1.
- the user may give an instruction to drive the arm unit 5 1 45 via the input device 5 1 6 1, and the imaging conditions (type of irradiation light, magnification and magnification) of the endoscope 5 1 15. Input the instruction to change the focal length, etc.) and the instruction to drive the energy treatment tool 5 1 3 5.
- the type of the input device 5 16 1 is not limited, and the input device 5 16 1 may be various known input devices.
- the input device 5 16 1 for example, a mouse, a keyboard, a touch panel, a switch, a foot switch 5 17 1 and/or a lever can be applied.
- the touch panel may be provided on the display surface of the display device 5 1 5 5.
- the input device 5 16 1 is a device worn by a user, such as a wearable device of a glasses type or a head mounted display (HMD), and a user detected by these devices. Various inputs are made according to the gesture and the line of sight.
- the input device 5 16 1 includes a camera capable of detecting the movement of the user, and various inputs are performed according to the user's gesture or line of sight detected from the image captured by the camera.
- the input device 516 1 includes a microphone capable of collecting the user's voice, and various inputs are performed by voice through the microphone.
- the input device 5 16 1 is configured to be able to input various kinds of information in a contactless manner, so that a user who belongs to a clean area (for example, a surgeon 5 1 8 1) is a device that belongs to a dirty area. ⁇ 02020/174865 46 ⁇ (: 170?2019/050965
- the user can operate the device without releasing his/her hand from the surgical tool, which improves the convenience of the user.
- the treatment instrument control device 5 1 63 controls the drive of the energy treatment instrument 5 1 35 for cauterization of tissue, incision, sealing of blood vessels, and the like.
- the pneumoperitoneum device 5 1 65 is used to expand the body cavity of the patient 5 1 8 5 for the purpose of securing a visual field by the endoscope 5 1 15 and a working space for the operator. 1 Inject gas into the body cavity through 33.
- the recorder 5 1 67 is a device that can record various information related to surgery.
- the printer 5 169 is a device capable of printing various information regarding surgery in various formats such as text, images, and graphs.
- the support arm device 5 1 41 includes a base portion 5 1 43 which is a base and an arm portion 5 1 45 extending from the base portion 5 1 43.
- the arm section 5 1 45 is composed of multiple joint sections 5 1 473, 5 1 47 5 1 47.
- a plurality of links 5 1 493, 5 1 49 which are connected by the joint 5 1 47 arm, but in FIG. 14 the arm portion 5 1 45 is composed for simplification.
- the direction of the rotation axis of 5 1 47 3 to 5 1 47 ⁇ can be appropriately set.
- the arm portion 145 may suitably be configured to have 6 or more degrees of freedom. This enables the endoscope 5 1 15 to move freely within the movable range of the arm 5 1 45, so that the lens barrel 5 1 1 7 of the endoscope 5 1 1 5 can be moved from a desired direction. Can be inserted into the body cavity of the patient 5 1 85.
- An actuator is provided in the joint part 5 1 47 3 to 5 1 47 ⁇ , and the joint part 5 1 47 3 to 5 1 47 ⁇ rotates in accordance with the drive of the actuator. ⁇ 02020/174865 47 ⁇ (: 170?2019/050965
- the drive of the actuator is controlled by the arm controller 5 15 9 to control the rotation angles of the joints 5 1 4 7 3 to 5 1 4 7 0 and control the drive of the arm 5 1 4 5. To be done. With this, control of the position and posture of the endoscope 5115 can be realized. At this time, the arm controller 5 159 can control the drive of the arm 5 14 5 by various known control methods such as force control or position control.
- the surgeon 5 1 8 1 makes an appropriate operation input via the input device 5 1 6 1 (including the foot switch 5 1 7 1), and the arm 5
- the controller 5 1 5 9 may appropriately control the driving of the arm 5 1 4 5 to control the position and posture of the endoscope 5 1 1 5.
- the endoscope 5 1 15 at the tip of the arm 5 14 5 can be moved from any position to any position and then fixedly supported at the position after the movement.
- the arm portions 5145 may be operated by a so-called master slave method.
- the arm unit 5 1 4 5 can be remotely operated by the user via the input device 5 1 6 1 installed at a place apart from the operating room.
- the arm control device 5 1 5 9 receives an external force from the user, and the arm portion 5 1 4 5 moves smoothly in accordance with the external force.
- each joint 5 1 4 7 3-5 1 4 Ru by driving the actuator of 7_Rei may perform a so-called power assist control. Accordingly, when the user moves the arm unit 5 1 45 while directly touching the arm unit 5 1 45, the arm unit 5 1 45 can be moved with a comparatively light force. Therefore, the endoscope 5115 can be moved more intuitively and with a simpler operation, and the convenience for the user can be improved.
- the arm control device 5 15 9 does not necessarily have to be provided in the force controller 5 1 5 1. Also, the arm control device 5 15 9 does not necessarily have to be one device.
- the arm control device 5 1 5 9 may be provided in each joint part 5 1 4 7a to 5 1 4 7 c of the arm part 5 1 4 5 of the support arm device 5 1 4 1, respectively.
- the drive control of the arm units 5 1 4 5 may be realized by the plurality of arm control devices 5 1 5 9 cooperating with each other.
- the light source device 5 1 5 7 supplies the endoscope 5 1 1 5 with irradiation light for imaging the surgical site.
- the light source device 5 15 7 is composed of, for example, an LED, a laser light source, or a white light source configured by a combination thereof.
- a white light source is configured by combining RGB laser light sources
- the output intensity and output timing of each color (each wavelength) can be controlled with high accuracy, so the light source device 5 1 5 7 It is possible to adjust the white balance of the captured image.
- the laser light from each of the RGB laser light sources should be applied to the observation target in a time-division manner, and the drive of the image sensor of the camera head 5 1 1 9 should be controlled in synchronization with the irradiation timing. This makes it possible to capture images corresponding to each of RGB in time division. According to this method, a color image can be obtained without providing a force filter on the image sensor.
- the drive of the light source devices 5 1 5 7 may be controlled so as to change the intensity of the output light at predetermined time intervals.
- the drive of the image sensor of the camera head 5 1 1 9 in synchronism with the timing of changing the light intensity, images are acquired in a time-sharing manner, and the images are combined to create so-called blackout and white areas. It is possible to generate an image with a high dynamic range without breaks.
- the light source devices 5 15 7 may be configured to be able to supply light in a predetermined wavelength band corresponding to special light observation.
- special light observation for example, the wavelength dependence of the absorption of light in body tissues is used to irradiate a narrow band of light as compared with the irradiation light (that is, white light) at the time of normal observation. High-contrast imaging of certain tissues such as blood vessels in d Imag i ng) is performed.
- fluorescence observation may be performed in which an image is obtained by fluorescence generated by irradiating the excitation light.
- the body tissue is irradiated with excitation light to observe fluorescence from the body tissue (autofluorescence observation), or a reagent such as indocyanine green (ICG) is locally injected into the body tissue and the body tissue is injected.
- a reagent such as indocyanine green (ICG) is locally injected into the body tissue and the body tissue is injected.
- the tissue may be irradiated with excitation light corresponding to the fluorescence wavelength of the reagent to obtain a fluorescent image.
- the light source device 5 15 7 can be configured to be able to supply the narrow band light and/or the excitation light corresponding to such special light observation.
- FIG. 15 is a block diagram showing an example of the functional configuration of the camera head 511 and CCU 5153 shown in FIG.
- the camera head 5 1 1 9 has, as its functions, a lens unit 5 1 2 1, an imaging unit 5 1 2 3, a driving unit 5 1 2 5 and a communication unit. It has a section 5 1 2 7 and a camera head control section 5 1 2 9.
- the CCU 5153 has, as its functions, a communication unit 5173, an image processing unit 5175, and a control unit 5177.
- the camera head 5 1 19 and the CCU 5 1 5 3 are connected by a transmission cable 5 1 7 9 so that they can communicate in both directions.
- the lens unit 5 1 2 1 is an optical system provided at a connection portion with the lens barrel 5 1 1 7.
- the observation light taken in from the tip of the lens barrel 5 1 1 7 is guided to the camera head 5 1 1 9 and enters the lens unit 5 1 2 1.
- the lens unit 5 1 2 1 is configured by combining a plurality of lenses including a zoom lens and a focus lens.
- the optical characteristics of the lens unit 5 1 2 1 are adjusted so that the observation light is condensed on the light receiving surface of the image pickup device of the image pickup unit 5 1 2 3.
- the zoom lens and the focus lens are configured so that their positions on the optical axis can be moved in order to adjust the magnification and focus of the captured image.
- the image pickup unit 5 1 2 3 is composed of an image pickup element, and the lens unit 5 1 2 1 It is placed in the latter stage.
- the observation light that has passed through the lens unit 5 1 2 1 is focused on the light-receiving surface of the image sensor, and photoelectric conversion generates an image signal corresponding to the observation image.
- the image signal generated by the imaging unit 5 1 2 3 is provided to the communication unit 5 1 2 7.
- CMOS Complementary Metal Oxide de Sem i conductor
- the imaging element for example, an imaging element that can be used to capture a high-resolution image of 4 K or more may be used. Since the image of the operative site is obtained with high resolution, the operator 518 1 can grasp the state of the operative site in more detail, and the operation can proceed more smoothly.
- the image pickup device forming the image pickup unit 5 1 2 3 is configured to have a pair of image pickup devices for respectively acquiring image signals for the right eye and the left eye corresponding to 3D display. ..
- the 3D display enables the operator 5 18 1 to more accurately grasp the depth of the living tissue in the operation site. If the image pickup unit 5 1 2 3 is composed of a multi-plate type, a plurality of lens units 5 1 2 1 are provided corresponding to each image pickup device.
- the imaging unit 5 1 2 3 does not necessarily have to be provided in the camera head 5 1 1 9.
- the imaging unit 5 1 2 3 may be provided inside the lens barrel 5 1 1 7 immediately after the objective lens.
- the drive unit 5 1 2 5 is composed of an actuator, and the zoom lens and the focus lens of the lens unit 5 1 2 1 are moved along the optical axis according to the control from the camera head control unit 5 1 2 9. Move only a distance. As a result, the magnification and focus of the imaged image by the imaging unit 5 1 2 3 can be adjusted appropriately.
- the communication unit 5 1 2 7 is composed of a communication device for transmitting and receiving various kinds of information to and from the CCU 5 1 5 3.
- the communication unit 5 1 2 7 sends the image signal obtained from the imaging unit 5 1 2 3 as RAW data to the CCU 5 1 5 3 via the transmission cable 5 1 7 9.
- the image signal is preferably transmitted by optical communication.
- the operator 5181 performs the operation while observing the state of the affected area by the captured images, so for safer and more reliable surgery, the moving image of the operation area should be as realistic as possible. This is because it is required to be displayed on Im.
- the communication unit 5 1 2 7 When optical communication is performed, the communication unit 5 1 2 7 is provided with a photoelectric conversion module that converts an electric signal into an optical signal. The image signal is converted into an optical signal by the photoelectric conversion module, and then transmitted to the CCU 5 15 3 via the transmission cable 5 17 9.
- the communication unit 5 1 2 7 receives a control signal for controlling the driving of the camera head 5 1 1 9 from the CCU 5 1 5 3.
- the control signal includes, for example, information that specifies the frame rate of the captured image, information that specifies the exposure value at the time of capturing, and/or information that specifies the magnification and focus of the captured image. It contains information about imaging conditions.
- the communication unit 5 1 2 7 provides the received control signal to the camera head control unit 5 1 2 9.
- the control signal from CCU 515 3 may also be transmitted by optical communication.
- the communication unit 5 1 2 7 is provided with a photoelectric conversion module that converts an optical signal into an electric signal, and the control signal is converted into an electric signal by the photoelectric conversion module and then the camera head control unit 5 Offered on 1 29.
- the imaging conditions such as the frame rate, the exposure value, the magnification, and the focus described above are automatically set by the control unit 5 1 7 7 of the CCU 5 15 3 based on the acquired image signal. That is, the so-called A E (Auto Exposure) function, A F (Auto Focus) function, and A W B (Auto White Balance) function are mounted on the endoscope 5 1 1 5.
- the camera head control unit 5 1 2 9 receives the C C U received via the communication unit 5 1 2 7.
- the drive of the camera head 5 1 1 9 is controlled based on the control signal from 5 1 5 3.
- the camera head control unit 5 1 2 9 may capture the image of the image capturing unit 5 1 2 3 based on the information indicating the frame rate of the captured image and/or the information indicating the exposure at the time of image capturing. Control the drive of the device.
- the camera head control unit 5 1 2 9 sets the magnification and focus of the captured image based on the information to be specified.
- the zoom lens and focus lens of the lens unit 5 1 2 1 are appropriately moved through the drive unit 5 1 2 5.
- the camera head controller 5 1 2 9 may further have a function of storing information for identifying the lens barrel 5 1 1 7 and the camera head 5 1 1 9.
- the camera head 5 1 1 9 can be automatically controlled. It can be made resistant to crepe sterilization.
- the communication unit 5 17 3 is composed of a communication device for transmitting and receiving various kinds of information to and from the camera head 5 1 1 9.
- the communication section 5 17 3 receives the image signal transmitted from the camera head 5 1 19 via the transmission cable 5 1 7 9.
- the image signal can be preferably transmitted by optical communication.
- the communication unit 5173 is provided with a photoelectric conversion module for converting an optical signal into an electric signal.
- the communication unit 5 17 3 provides the image signal converted to an electric signal to the image processing unit 5 17 5.
- the communication unit 5 17 3 is different from the camera head 5 1 1 9 in that
- the control signal may also be transmitted by optical communication.
- the image processing unit 5175 performs various types of image processing on the image signal which is the RA W data transmitted from the camera head 5 1 19. Examples of the image processing include development processing, high image quality processing (band enhancement processing, super-resolution processing, NR (Noise reduction) processing and/or camera shake correction processing), and/or enlargement processing ( Electronic zoom processing), and various other known signal processing are included. Further, the image processing unit 5175 performs detection processing on the image signal for performing A E, A F, and A W B.
- the image processing unit 5175 is composed of a processor such as a CPU and a GPU, and the image processing and detection processing described above can be performed by the processor operating according to a predetermined program.
- the image processing unit 5 1 7 5 has multiple G ⁇ 0 2020/174865 53 ⁇ (: 170?2019/050965
- the image processing unit 5175 When configured by II, the image processing unit 5175 appropriately divides information related to the image signal and performs image processing in parallel by the plurality of II.
- the control unit 5 17 7 carries out various controls relating to the imaging of the surgical site by the endoscope 5 1 15 and the display of the captured image. For example, the control unit 5 17 7 generates a control signal for controlling the driving of the camera head 5 1 1 7. At this time, when the imaging condition is input by the user, the control unit 517 7 generates a control signal based on the input by the user. Alternatively, when the endoscope 5 1 15 is equipped with the eight-axis function, the function, and the number-of-fault function, the control unit 5 1 7 7 controls the image processing unit 5 1 7 5 according to the detection processing result. , The optimum exposure value, focal length and white balance are calculated as appropriate, and the control signal is generated.
- control unit 5 17 7 causes the display device 5 1 5 5 to display the image of the operation unit based on the image signal subjected to the image processing by the image processing unit 5 1 7 5.
- the control unit 517 recognizes each kind of object in the operative image by using various image recognition techniques. For example, the control unit 5 17 7 detects the shape and color of the edge of the object included in the surgical region image to determine the surgical instrument such as forceps, a specific living body part, bleeding, energy treatment device 5 1 3 5 It is possible to recognize the mist, etc. during use.
- the control unit 517 uses the recognition result to superimpose and display various types of surgical support information on the image of the operative site. By displaying the surgery support information in a superimposed manner and presenting it to the operator 5181, it becomes possible to proceed with the surgery more safely and reliably.
- Ke _ Bull is an electrical signal Ke _ Bull corresponding to the communication of electrical signals, light off Aiba corresponding to optical communication, or a composite cable.
- wired communication was performed using the transmission cable 5179, but communication between the camera head 511 It may be performed wirelessly. If the communication between the two is performed wirelessly, it is not necessary to lay the transmission cable 5179 in the operating room, and therefore the movement of medical staff in the operating room is hindered by the transmission cable 5179. The situation is solved Can be erased.
- the example of the operating room system 510 to which the technology according to the present disclosure can be applied has been described above.
- the case where the medical system to which the operating room system 510 is applied is the endoscopic surgery system 5113 is explained.
- the configuration of the operating room system 510 is as follows. It is not limited to such an example.
- the operating room system 5100 may be applied to a flexible endoscopic system for examination or a microscopic surgery system instead of the endoscopic surgery system 5113.
- the technique according to the present disclosure includes the ceiling camera 5 18 among the configurations described above.
- a 7 or a surgical field camera 189 or an endoscope can be suitably applied to a 7 or a surgical field camera 189 or an endoscope.
- imaging devices such as these cameras and endoscopes, and variable focal length lens systems in these imaging devices.
- the technology according to the present disclosure can be applied to various products.
- the technology related to this disclosure may be any of automobiles, electric vehicles, hybrid electric vehicles, motorcycles, bicycles, personal mobility, airplanes, drones, ships, robots, construction machinery, agricultural machinery (tractors), etc. It may be applied to an image pickup device or a variable focal length lens system mounted on a moving body of this type.
- FIG. 16 is a block diagram showing a schematic configuration example of a vehicle control system 700 that is an example of a mobile body control system to which the technology according to the present disclosure can be applied.
- the vehicle control system 700 includes a plurality of electronic control units connected via a communication network 7100.
- the vehicle control system 700 is a drive system control unit 7100, a body system control unit 7200, a battery control unit 7300, and vehicle exterior information.
- a detection unit 7400, an in-vehicle information detection unit 7500, and an integrated control unit 7600 are provided.
- a communication network for connecting these control units is, for example, CAN (Con troller Area Network), LIN (Local Interconnect Network), LAN (Local Area Network) or FI ex R ay (registered trademark ), etc., may be an in-vehicle communication network that complies with any standard.
- Each control unit includes a microcomputer that performs arithmetic processing according to various programs, a storage unit that stores a program executed by a microcomputer or parameters used for various arithmetic operations, and devices to be controlled. And a drive circuit for driving.
- Each control unit is equipped with a network/F for communicating with other control units via the communication network 7010, and also with devices inside or outside the vehicle, sensors, etc. It is equipped with a communication system /F for performing communication by wire communication or wireless communication.
- the functional configuration of the integrated control unit 7600 is as follows: Microcomputer 7610, General-purpose communication I/F 7620, Dedicated communication I/F 7630, Positioning unit 7640, Beacon receiving unit 7650, In-vehicle device I/F 7660 The audio/video output unit 7670, the in-vehicle network I/F 7680, and the storage unit 7690 are illustrated. Similarly, the other control units are also equipped with a microcomputer, communication/F, and storage.
- the drive system control unit 7100 controls the operation of devices related to the drive system of the vehicle according to various programs.
- the drive system control unit 7100 is a drive force generation device for generating drive force of a vehicle such as an internal combustion engine or a drive motor, a drive force transmission mechanism for transmitting drive force to wheels, It functions as a steering mechanism that adjusts the steering angle and as a control device such as a braking device that generates the braking force of the vehicle.
- the drive system control unit 7100 may have a function as a control device such as an ABS (Anti lock Brake System) or an ESC (Electronic Stability Control).
- the vehicle state detection unit 711 is connected to the drive system control unit 710.
- the vehicle state detection unit 7 1 1 1 0 includes, for example, a gyro sensor that detects the angular velocity of the shaft rotational movement of the vehicle body, an acceleration sensor that detects the acceleration of the vehicle, or the operation amount of the axel pedal, the operation amount of the brake pedal, and the steering At least one of the sensors for detecting the steering angle of the wheel, the engine speed, the rotational speed of the wheel, etc. is included.
- the drivetrain control unit 7 100 is The arithmetic processing is performed by using the signal input from the detection unit 7110, and the internal combustion engine, the drive motor, the electric power steering device, the brake device, and the like are controlled.
- the body system control unit 7200 controls the operation of various devices mounted on the vehicle body according to various programs.
- the body system control unit 720 is used as a keyless entry system, smart key system, power window device, or as a control device for various lamps such as headlamps, back lamps, brake lamps, win-win or fog lights. Function.
- radio waves or signals from various switches transmitted from a portable device that substitutes for a key can be input to the body system control unit 700.
- the body system control unit 7200 receives these radio waves or signals and controls the vehicle door lock device, power window device, lamp, and the like.
- the battery control unit 7300 controls the secondary battery 7310 that is a power supply source for the drive mode according to various programs. For example, information such as the battery temperature, the battery output voltage, or the remaining capacity of the battery is input to the battery control unit 7300 from the battery device including the secondary battery 7310. The battery control unit 7300 performs arithmetic processing using these signals to control the temperature of the secondary battery 7310 or the cooling device provided in the battery device.
- the vehicle exterior information detection unit 740 detects information outside the vehicle equipped with the vehicle control system 7000.
- the image pickup unit 7410 and the exterior information detection unit 7420 is connected to the exterior information detection unit 7400.
- the image capturing unit 741 includes at least one of a T F (T i Me Of F l i ght) camera, a stereo camera, a monocular camera, an infrared camera and other cameras.
- the vehicle exterior information detection unit 7420 includes, for example, an environment sensor for detecting the current weather or the weather, or another vehicle around the vehicle equipped with the vehicle control system 70000, an obstacle, or an obstacle. At least one of the surrounding information detection sensors for detecting a pedestrian or the like is included.
- the environment sensor is, for example, a raindrop sensor that detects rainy weather, or a fog sensor that detects fog. At least one of a sun sensor, a sun sensor that detects the degree of sunshine, and a snow sensor that detects snowfall.
- the ambient information detection sensor may be at least one of an ultrasonic sensor, a radar device, and a L DAR (Light Detection and Ranging, Laser Imaging Detection and Ranging) device.
- the image pickup unit 74 10 and the vehicle exterior information detection unit 7420 may be provided as independent sensors or devices, or may be provided as a device in which a plurality of sensors or devices are integrated.
- Fig. 17 shows an example of the installation positions of the imaging unit 7410 and the vehicle exterior information detection unit 7420.
- the imaging unit 79 1 0, 79 1 2, 79 1 4, 79 1 6, 79 1 8 is, for example, at least one of the front nose of the vehicle 7900, the side mirror, the rear bumper, the back door, and the upper part of the windshield inside the vehicle. It is provided in one position.
- the image pickup unit 79 10 provided on the front nose and the image pickup unit 79 18 provided on the upper part of the windshield in the vehicle interior mainly acquire images in front of the vehicle 7900.
- the imaging unit 79 1 2, 7 9 14 provided in the side mirror mainly acquires an image of the side of the vehicle 7900.
- the image pickup unit 79 16 provided in the rear bumper or the back door mainly acquires an image of the rear of the vehicle 7900.
- the imaging unit 79 18 provided on the upper part of the windshield inside the vehicle is mainly used for detecting a preceding vehicle or a pedestrian, an obstacle, a traffic signal, a traffic sign or a lane.
- Imaging range a indicates the imaging range of the imaging unit 79 10 provided on the front nose
- imaging ranges b and c indicate the imaging range of the imaging units 79 1 2, 79 1 4 provided on the side mirrors, respectively.
- the image pickup range d indicates the image pickup range of the image pickup section 79 16 provided on the rear bumper or the back door. For example, by superimposing the image data taken by the imaging units 79 1 0, 79 1 2, 79 1 4, 79 16 on top of each other, a bird's-eye view of the vehicle 7900 from above can be obtained.
- the vehicle exterior information detectors 7 9 2 0, 7 9 2 2, 7 9 2 4, 7 9 2 6, 7 9 2 8 and 7 9 30 provided on the top of the lath are, for example, ultrasonic sensors or radar devices. You may The vehicle exterior information detectors 7 9 2 0 ,7 9 2 6 ,7 9 3 0 provided on the front nose, rear bumper, back door and upper windshield of the vehicle 7900 are, for example, 1_ It may be a device. These outside-vehicle information detection units 7920 to 7930 are mainly used to detect a preceding vehicle, a pedestrian, an obstacle, or the like.
- the exterior information detection unit 7400 is
- the image of the outside of the vehicle is captured by the 7410, and the captured image data is received.
- the vehicle exterior information detection unit 7400 receives the detection information from the vehicle exterior information detection unit 7420 connected to the vehicle exterior information detection unit 7400.
- the vehicle exterior information detection unit 7420 is an ultrasonic sensor, radar device or !_ ⁇
- the vehicle exterior information detection unit 7400 transmits ultrasonic waves or electromagnetic waves and receives them. Receives the reflected wave information.
- the vehicle exterior information detection unit 740 may perform object detection processing or distance detection processing such as people, vehicles, obstacles, signs, or characters on the road surface based on the received information.
- the exterior information detection unit 7400 may perform environment recognition processing for recognizing rainfall, fog, road surface conditions, etc. based on the received information.
- the vehicle exterior information detection unit 7400 may calculate the distance to an object outside the vehicle based on the received information.
- the exterior information detection unit 740 performs image recognition processing or distance detection processing that recognizes people, vehicles, obstacles, signs, characters on the road surface, etc. based on the received image data. You can go.
- the exterior information detection unit 7400 performs processing such as distortion correction or position adjustment on the received image data, and combines the image data captured by different image capturing units 7410. An overhead image or a panoramic image may be generated.
- the vehicle exterior information detection unit 7400 may perform viewpoint conversion processing using image data captured by different image capturing units 7410.
- the in-vehicle information detection unit 750 detects in-vehicle information.
- In-vehicle information detection The unit 7500 is connected to, for example, a driver state detection unit 7510 that detects the state of the driver.
- the driver state detection unit 7510 may include a camera for capturing an image of the driver, a biometric sensor for detecting biometric information of the driver, a microphone for collecting voice in the vehicle, and the like.
- the biometric sensor is provided on, for example, a seat surface or a steering wheel, and detects biometric information of a passenger sitting in a seat or a driver who holds a steering wheel.
- the in-vehicle information detection unit 750 may calculate the degree of fatigue or concentration of the driver based on the detection information input from the driver state detection unit 750. You may decide whether you are sleeping or not. The in-vehicle information detection unit 750 may perform processing such as noise canceling processing on the collected audio signal.
- the integrated control unit 760 controls overall operations in the vehicle control system 7000 according to various programs.
- An input unit 780 is connected to the integrated control unit 760.
- the input unit 780 is realized by a device such as a touch panel, a button, a microphone, a switch or a lever that can be operated by a passenger.
- the integrated control unit 760 may be input with data obtained by voice recognition of voice input by Microphone.
- the input unit 7800 may be, for example, a remote control device using infrared rays or other radio waves, or may be a mobile phone or a PDA (Personal lDigi) that supports the operation of the vehicle control system 7800. It may be an externally connected device such as ta l Assistant).
- the input unit 780 may be, for example, a camera, in which case the passenger can input information by gesture. Alternatively, the data obtained by detecting the movement of the wearable device worn by the passenger may be input. Further, the input unit 780 generates an input signal based on the information input by the passenger using the input unit 780 described above, and outputs the input signal to the integrated control unit 760. It may include an input control circuit for outputting. A passenger or the like operates the input unit 780 to input various data or instruct a processing operation to the vehicle control system 7000. [0257]
- the storage unit 7690 includes a ROM (Read Only Memory) for storing various programs executed by the microcomputer, and a RAM (Random Access Memory) for storing various parameters, calculation results, sensor values, and the like. You may stay.
- the storage unit 7690 may be realized by a magnetic storage device such as an HDD (Hard Disc Drive), a semiconductor storage device, an optical storage device, a magneto-optical storage device, or the like.
- the general-purpose communication I/F 7620 is a general-purpose communication I/F /F that mediates communication with various devices existing in the external environment 7750.
- General-purpose communication I/F 7620 is compatible with GSM (registered trademark) (Global System of Mobile communications) % W i MAX (registered trademark), LTE (registered trademark) (Long Term Evolution) or LT E— A (LTE- A cellular communication protocol such as Advanced) or a wireless LAN (also referred to as Wi-Fi (registered trademark)), or other wireless communication protocol such as Bluetooth (registered trademark) may be implemented.
- GSM Global System of Mobile communications
- % W i MAX registered trademark
- LTE registered trademark
- LT E— A LTE- A cellular communication protocol such as Advanced
- a wireless LAN also referred to as Wi-Fi (registered trademark)
- other wireless communication protocol such as Bluetooth (registered trademark) may be implemented.
- a general-purpose communication device/F 7620 is a device (for example, the device existing on the external network (for example, the Internet, the cloud network or the network unique to the operator)) via the base station or the access point (for example, Application server or control server).
- the general-purpose communication system /F 7620 uses, for example, P 2 P (Peer To Peer) technology to connect terminals (e.g., drivers, pedestrians or shops, or MTC (Machine Type Communic at ion) terminal).
- the dedicated communication/F 7630 is a communication/F that supports a communication protocol designed for use in vehicles.
- the dedicated communication I/F 7630 is, for example, WAVE (Wi re less Access in Vehicle Environment), which is a combination of the lower layer EEE 802.1 p and the upper layer EEE 1 609, and the DSRC (Dedicated Short Range). Communications) % or cellular communication protocols may be implemented.
- Dedicated communication/F 7630 is typically used for vehicle-to-vehicle communication, vehicle-to-vehicle communication, and vehicle-to-house communication.
- V 2 X communication which is a concept that includes one or more of ome) communication and Vehicle to Pedestrian communication.
- the positioning unit 7640 executes positioning, for example, by receiving a G NSS signal from a GNSS (Global Navigation Satellite System) satellite (for example, a G PS signal from a G PS (Global Positioning System) satellite), Generates location information including vehicle latitude, longitude and altitude.
- a G NSS signal from a GNSS (Global Navigation Satellite System) satellite
- G PS Global Positioning System
- the positioning unit 7640 may specify the current position by exchanging a signal with a wireless access point, or may acquire position information from a terminal having a positioning function, such as a mobile phone, PHS, or smartphone.
- the beacon receiving unit 7650 receives, for example, a radio wave or an electromagnetic wave transmitted from a wireless station or the like installed on a road, and acquires information such as the current position, traffic jam, traffic closure, or required time.
- the function of the beacon receiving unit 7650 may be included in the above-described dedicated communication/F 7630.
- the in-vehicle device/F 7660 is a communication interface that mediates a connection between the micro computer 7610 and various in-vehicle devices 7760 existing in the vehicle.
- the in-vehicle device I/F 7660 may establish a wireless connection using a wireless communication protocol such as a wireless LAN, Bluetooth (registered trademark), NFC (Near Field Communication), or WUSB (Wireless U SB).
- the in-vehicle device /F 7660 can be connected to the USB (Universal Serial Bus), HDMI (registered trademark) (High-Definition Multimedia Interface, Alternatively, a wired connection such as MH L (Mobile Hi-definition Link) may be established.
- the in-vehicle device 7760 is, for example, a mobile device or a wearable device that the passenger has, or an information device that is carried in or attached to the vehicle.
- the in-vehicle device 7760 may include a navigation device for route search to any destination.
- the in-vehicle device/F 7660 may be a navigation device.
- the in-vehicle network/F 760 is an interface that mediates communication between the micro computer 760 and the communication network 710.
- the on-board network/F 760 sends and receives signals, etc. according to a predetermined protocol supported by the communication network 710.
- the integrated control unit 7600's micro-computer 7600 is for general-purpose communication.
- the vehicle control system 7000 is controlled according to various programs based on the information acquired through at least one of the 680.
- the micro computer 760 calculates the control target value of the driving force generation device, the steering mechanism or the braking device based on the acquired information on the inside and outside of the vehicle, and the drive system control unit 710.
- a control command may be output for 0.
- the micro computer 760 includes ADAS (Advanced Drone) that includes vehicle collision avoidance or impact mitigation, vehicle-based follow-up driving, vehicle speed maintenance driving, vehicle collision warning, and vehicle lane departure warning.
- ADAS Advanced Drone
- i ver Ass i stance System may be performed for cooperative control.
- the micro-computer 760 controls the driving force generator, steering mechanism, braking device, etc. based on the acquired information about the surroundings of the vehicle, so that it does not depend on the driver's operation. Coordinated control may be performed for the purpose of automatically driving the vehicle.
- Microcomputer 7 6 10 is for general-purpose communication / F 7 6 20, dedicated communication I / F 7 6 30, positioning unit 7 6 4 0, beacon receiving unit 7 6 5 0, in-vehicle device I / Based on the information acquired via at least one of the F 760 and in-vehicle network I / F 760, the 3D between the vehicle and the surrounding structures or objects such as people.
- the distance information may be generated and the local map information including the peripheral information of the current position of the vehicle may be generated.
- the micro computer 760 may generate a warning signal by predicting a danger such as a vehicle collision, a proximity of a pedestrian or the like, or an approach to a closed road, based on the acquired information.
- the warning signal may be, for example, a signal for generating a warning sound or lighting a warning lamp. Yes.
- the audio/video output unit 760 provides at least one of audio and image to an output device capable of visually or audibly notifying information to a passenger of the vehicle or the outside of the vehicle. Send the output signal of.
- an audio speaker 7710, a display unit 7720, and an instrument panel 7730 are illustrated as output devices.
- the display unit 7720 may include at least one of an onboard display and a head-up display, for example.
- the display unit 7720 may have an A R (Augmented Reality) display function.
- the output device may be a headphone, a wearable device such as a glasses-type display worn by a passenger, a projector, or another device such as a lamp.
- the display device displays the results obtained by various processes performed by the microcomputer 7610 or the information received from another control unit as text, images, tables, and graphs. Visually display in various formats such as.
- the audio output device converts an audio signal composed of reproduced audio data or acoustic data into an analog signal and outputs it audibly.
- At least two control units connected via the communication network 710 may be integrated as one control unit.
- each control unit may be composed of multiple control units.
- the vehicle control system 700 may include another control unit (not shown).
- some or all of the functions of one of the control units may be given to another control unit. That is, as long as information is transmitted and received via the communication network 710, the predetermined arithmetic processing may be performed by any one of the control units.
- a sensor or device that is connected to one of the control units is connected to another control unit, and multiple control units can detect each other over the communication network 710. You may send and receive information. ⁇ 02020/174865 64 ⁇ (: 170?2019/050965
- the present technology may also be configured as below.
- a first lens unit including at least one lens group, a second lens unit including a first free-form surface lens and a second free-form surface lens, and at least one lens It consists of a third lens unit consisting of
- the first lens unit and the third lens unit are composed of lenses having a shape symmetrical with respect to the optical axis and are arranged on the same optical axis,
- the first free-form surface lens and the second free-form surface lens have the same shape and are arranged by rotating 180 degrees with respect to the optical axis,
- the optical axes of the first lens unit and the third lens unit are axes, the axis perpendicular to the axis on the image plane is the vertical axis, and the axis perpendicular to the axis on the image plane is the X axis.
- the first free-form surface lens and the second free-form surface lens are movable in the axial direction
- the refracting power of the second lens unit is variable
- the lens position changes from the wide-angle end state where the focal length is the shortest to the telephoto end state where the focal length is the longest, part of the lens groups that make up the first lens unit and the third lens unit. And the first free-form surface lens and the second free-form surface lens move in the axial direction.
- variable focal length lens system according to ⁇ 1>.
- variable focal length lens system according to ⁇ 2>.
- ⁇ !_ _ The amount of movement of the second free-form surface lens in the vertical axis direction from the wide-angle end state to the telephoto end state.
- An aperture stop is arranged near the second lens unit
- variable focal length lens system according to ⁇ 3>.
- ⁇ Maximum value along the axis from the aperture stop to the second lens unit%: Focal length of the entire lens system in the wide-angle end state
- variable focal length lens system according to ⁇ 4>.
- ⁇ !_ _ The amount of movement of the second free-form surface lens in the vertical axis direction from the wide-angle end state to the telephoto end state.
- the first lens unit has, in order from the object side to the image side, a first lens group having a positive refractive power and a second lens group having a negative refractive power,
- the distance between the first lens group and the second lens group increases, and the second lens unit and the second lens unit are separated from each other. At least the second lens group moves in the optical axis direction so that the distance decreases.
- variable focal length lens system according to ⁇ 5>.
- the third lens unit includes a focusing lens that moves in the optical axis direction according to the subject distance.
- variable focal length lens system according to ⁇ 6>.
- variable focal length lens system and an image sensor for converting an optical image formed by the variable focal length lens system into an electrical signal
- variable focal length lens system The variable focal length lens system
- the first lens unit is composed of at least one lens group
- the second lens unit is composed of the first and second free-form surface lenses.
- the first lens unit and the third lens unit are composed of lenses having a shape symmetrical with respect to the optical axis and are arranged on the same optical axis,
- the first free-form surface lens and the second free-form surface lens have the same shape and are arranged by rotating 180 degrees with respect to the optical axis,
- the optical axes of the first lens unit and the third lens unit are axes, the axis perpendicular to the axis on the image plane is the vertical axis, and the axis perpendicular to the axis on the image plane is the X axis.
- the first free-form surface lens and the second free-form surface lens are movable in the axial direction
- the refracting power of the second lens unit is variable
- the lens position changes from the wide-angle end state where the focal length is the shortest to the telephoto end state where the focal length is the longest, part of the lens groups that make up the first lens unit and the third lens unit. And the first free-form surface lens and the second free-form surface lens move in the axial direction.
- variable focal length lens system 2 variable focal length lens system, 3 variable focal length lens system, II 1 1st lens unit, II 2 2nd lens unit, II 3 3rd lens unit, ⁇ 1 1st lens group, ⁇ 2 2nd lens group, 0 3 3rd lens group, 0 4 4th lens group, 0 5 5th lens group, 0 6 6th lens group, 0 7 7th lens group, 0 8 8th lens group,! _ 3 1st free-form surface lens, 1_ 4 2nd free-form surface lens, 3 aperture stop, 100 imaging device, 10 imaging device
Landscapes
- Physics & Mathematics (AREA)
- General Physics & Mathematics (AREA)
- Optics & Photonics (AREA)
- Lenses (AREA)
Abstract
Description
明 細 書 Specification
発明の名称 : 可変焦点距離レンズ系及び撮像装置 Title of invention: Variable focal length lens system and imaging device
技術分野 Technical field
[0001] 本技術は、 デジタルビデオカメラやデジタルスチルカメラ等に使用される 可変焦点距離レンズ系及びこのような可変焦点距離レンズ系を用いた撮像装 置に関する。 特に、 本技術は、 画角が最も広くなる広角端状態で 24〜 38 mm程度 (35 mm換算) 、 Fナンバーが 1. 8〜 4. 0程度、 ズーム比が 1 〇〜 30倍程度のズームレンズに適している。 The present technology relates to a variable focal length lens system used in a digital video camera, a digital still camera, and the like, and an imaging device using such a variable focal length lens system. In particular, this technology uses a zoom of about 24 to 38 mm (35 mm equivalent), an F number of about 1.8 to 4.0, and a zoom ratio of about 10 to 30 times in the wide-angle end state where the angle of view is widest. Suitable for lenses.
背景技術 Background technology
[0002] 従来より、 カメラにおける記録手段として、 CCD (Charge Coupled Devi ce) や CMOS (Complementary Meta l Oxide Semiconductor) 等の光電変換 素子を用いた撮像素子によって、 撮像素子面上に形成された被写体像を各光 電変換素子によって被写体像の光量を電気的出力に変換して記録する方法が 知られている。 [0002] Conventionally, as a recording means in a camera, a subject image formed on an image sensor surface by an image sensor using a photoelectric conversion element such as CCD (Charge Coupled Device) or CMOS (Complementary Metal Oxide Semiconductor). There is known a method of recording light by converting the light amount of a subject image into an electric output by each photoelectric conversion element.
[0003] 近年の微細加工技術の技術進歩に伴い、 中央演算処理装置 (C P U) の高 速化や記憶媒体の高集積化が図られ、 それまでは取り扱えなかったような大 容量の画像データが高速処理できるようになってきた。 特に、 C P Uの高速 化により、 歪曲収差や倍率色収差と言った収差補正が撮影後に本体内で行わ れるようになってきた。 [0003] With recent technological advances in microfabrication technology, the speed of central processing unit (CPU) and the integration of storage media have been increased, and large-capacity image data that could not be handled up to that point was created. High-speed processing has become possible. In particular, due to the increased speed of CPU, aberration correction such as distortion and lateral chromatic aberration has come to be performed inside the main body after shooting.
[0004] ところで、 従来のズームレンズは複数の可動レンズ群を有し、 それらの可 動レンズ群を光軸方向へ移動させることで像面位置を一定に保ったまま、 焦 点距離を変化させている (例えば、 特許文献 1参照) 。 By the way, a conventional zoom lens has a plurality of movable lens groups, and the movable lens groups are moved in the optical axis direction to change the focal length while keeping the image plane position constant. (For example, see Patent Document 1).
[0005] 特許文献 1 に記載されたズームレンズは、 物体側より像側へ順に、 正の屈 折力を有する第 1 レンズ群と、 負の屈折力を有する第 2レンズ群と、 正の屈 折力を有する第 3レンズ群と、 正の屈折力を有する第 4レンズ群とにより構 成されている。 このズームレンズにおいては、 焦点距離を変化させる際に、 第 1 レンズ群と第 3レンズ群が固定で、 第 2レンズ群が光軸方向へ移動し、 \¥02020/174865 2 卩(:170?2019/050965 The zoom lens described in Patent Document 1 includes, in order from the object side to the image side, a first lens group having a positive refractive power, a second lens group having a negative refractive power, and a positive lens group. It is composed of a third lens group having a folding power and a fourth lens group having a positive refractive power. In this zoom lens, when changing the focal length, the first lens group and the third lens group are fixed, the second lens group moves in the optical axis direction, \¥02020/174865 2 (:170?2019/050965
それに伴う像面位置の変化を補償するように第 4レンズ群が光軸方向へ移動 する。 The fourth lens group moves in the optical axis direction so as to compensate for the accompanying change in the image plane position.
[0006] これに対して、 回転対称な軸を持たない自由曲面レンズを光軸に垂直な方 向へ移動させて画角を変化させるスライ ド式の可変焦点距離レンズ系が知ら れている (例えば、 特許文献 2参照) 。 特許文献 2に記載された可変焦点距 離レンズ系においては、 4枚の自由曲面レンズが移動してズーム操作が行わ れている。 [0006] On the other hand, a sliding variable focal length lens system is known in which a free-form surface lens having no rotationally symmetric axis is moved in a direction perpendicular to the optical axis to change the angle of view. For example, refer to Patent Document 2). In the variable focal length lens system described in Patent Document 2, four free-form lenses move to perform a zoom operation.
先行技術文献 Prior art documents
特許文献 Patent literature
[0007] 特許文献 1 :特開平 4 _ 4 3 3 1 1号公報 [0007] Patent Document 1: Japanese Patent Laid-Open No. 4_4 3 3 1 1
特許文献 2 :特開 2 0 0 7 _ 4 0 6 3号公報 発明の開示 Patent Document 2: Japanese Unexamined Patent Application Publication No. 2000-7_44063 Disclosure of Invention
発明が解決しようとする課題 Problems to be Solved by the Invention
[0008] しかしながら、 従来のズームレンズではレンズ全長の短縮化に限界があっ た。 [0008] However, the conventional zoom lens has a limit in reducing the total lens length.
[0009] これまでに提案された自由曲面レンズを使った可変焦点距離レンズ系では 、 例えば、 特許文献 2におけるレンズ系では、 2か所に自由曲面レンズを 2 枚ずつ配置することでズーム部とコンペンゼータ部に分離し、 それぞれ異な る方向へ移動させることにより、 変倍を行っている。 [0009] In the variable focal length lens system using the free-form surface lens that has been proposed so far, for example, in the lens system in Patent Document 2, by disposing two free-form surface lenses at two locations, respectively Zooming is performed by separating the compensator part and moving it in different directions.
[0010] ところが、 自由曲面レンズが 4枚と非常に多く、 自由曲面は加工が難しい ために、 製造を含めて安定した光学品質を得ることが難しかった。 また、 そ れらが独立して移動するために、 位置制御も難しいという課題があった。 [0010] However, since there are a large number of free-form surface lenses, and it is difficult to process the free-form surface lenses, it was difficult to obtain stable optical quality including manufacturing. In addition, there is a problem that position control is difficult because they move independently.
[001 1 ] そこで、 本技術の可変焦点距離レンズ系及び撮像装置は、 小型で高倍率な 可変焦点距離レンズ系及び撮像装置を提供することを目的とする。 Therefore, an object of the variable focal length lens system and the image pickup apparatus of the present technology is to provide a small-sized and high-magnification variable focal length lens system and an image pickup apparatus.
課題を解決するための手段 Means for solving the problem
[0012] 第 1 に、 本技術に係る可変焦点距離レンズ系は、 物体側より像側へ順に、 少なくとも一つのレンズ群で構成される第 1 レンズユニッ トと、 第 1 自由曲 \¥02020/174865 3 卩(:170?2019/050965 [0012] First, the variable focal length lens system according to the present technology includes a first lens unit composed of at least one lens group in order from the object side to the image side, and a first free-form lens. \¥02020/174865 3 卩 (: 170?2019/050965
面レンズと第 2自由曲面レンズで構成される第 2レンズユニッ トと、 少なく とも一つのレンズ群で構成される第 3レンズユニッ トとにより構成され、 前 記第 1 レンズユニッ トと前記第 3レンズユニッ トは光軸に対して回転対称な 形状のレンズで構成されると共に同じ光軸上に配置され、 前記第 1 自由曲面 レンズと前記第 2自由曲面レンズは同一形状にされ光軸に対して 1 8 0度回 転して配置され、 前記第 1 レンズユニッ トと前記第 3レンズユニッ トの光軸 を 軸とし、 像面上で 軸に垂直な軸を丫軸とし、 像面上で丫軸と 軸に垂 直な軸を乂軸とすると、 前記第 1 自由曲面レンズと前記第 2自由曲面レンズ は丫軸方向へ移動可能であり、 前記第 1 自由曲面レンズと前記第 2自由曲面 レンズが互いに逆方向へ移動することにより前記第 2レンズユニッ トの屈折 力が可変であり、 焦点距離が最も短い広角端状態から焦点距離が最も長い望 遠端状態までレンズの位置状態が変化する際に、 前記第 1 レンズユニッ トと 前記第 3レンズユニッ トを構成するレンズ群の一部が移動するのと合わせて 、 前記第 1 自由曲面レンズと前記第 2自由曲面レンズが丫軸方向へ移動する ものである。 A second lens unit composed of a surface lens and a second free-form surface lens, and a third lens unit composed of at least one lens group. The first lens unit and the third lens unit described above are used. The lens unit is composed of lenses that are rotationally symmetric with respect to the optical axis and is arranged on the same optical axis.The first free-form surface lens and the second free-form surface lens have the same shape and The optical axis of the first lens unit and the third lens unit is the axis, and the axis perpendicular to the axis on the image plane is the vertical axis and the axis on the image plane is the vertical axis. When the vertical axis and an axis perpendicular to the axis are the vertical axes, the first free-form surface lens and the second free-form surface lens are movable in the vertical axis direction, and the first free-form surface lens and the second free-form surface lens are movable. By moving the lenses in opposite directions, the refractive power of the second lens unit is variable, and the position of the lens changes from the wide-angle end state with the shortest focal length to the telephoto end state with the longest focal length. At this time, the first free-form surface lens and the second free-form surface lens are moved in the direction of the vertical axis along with the movement of a part of the lens group forming the first lens unit and the third lens unit. It is something that moves.
[0013] これにより、 第 1 自由曲面レンズと第 2自由曲面レンズが互いに逆方向へ 移動することにより第 2レンズユニッ トの合成屈折力が変化すると共に第 1 自由曲面レンズと第 2自由曲面レンズが逆方向へ同じ量だけ移動されること により非対称な形状に起因する収差が第 1 自由曲面レンズと第 2自由曲面レ ンズの二つのレンズで互いに打ち消し合う。 [0013] As a result, the first free-form surface lens and the second free-form surface lens move in opposite directions to change the combined refractive power of the second lens unit, and at the same time, the first free-form surface lens and the second free-form surface lens. By moving by the same amount in the opposite direction, the aberrations caused by the asymmetrical shape cancel each other out in the two lenses, the first free-form surface lens and the second free-form surface lens.
[0014] 第 2に、 上記した可変焦点距離レンズ系においては、 下記の条件式 ( 1 ) を満足することが望ましい。 Secondly, in the variable focal length lens system described above, it is desirable that the following conditional expression (1) is satisfied.
( 1 ) 0 . 0 3 <八 2/å<0. 3 5 (1) 0 .0 3 <8 2/å <0.3 5
但し、 However,
△ 2 : ø 27/¢ 2 △ 2: ø 27/¢ 2
¢27 :望遠端状態における第 2レンズユニッ トの屈折力 ¢27: Refracting power of the 2nd lens unit in the telephoto end state
0 :広角端状態における第 2レンズユニッ トの屈折力 0: Refracting power of the second lens unit in the wide-angle end state
å : 干 1: /干 \¥02020/174865 4 卩(:170?2019/050965 å: dried 1: / dried \¥02020/174865 4 (: 170?2019/050965
干 1 :望遠端状態におけるレンズ系全体の焦点距離 D 1: Focal length of the entire lens system in the telephoto end state
干% :広角端状態におけるレンズ系全体の焦点距離 %: Focal length of the entire lens system in the wide-angle end state
とする。 And
[0015] これにより、 望遠端状態で発生する色収差が抑制される。 [0015] This suppresses chromatic aberration that occurs in the telephoto end state.
[0016] 第 3に、 上記した可変焦点距離レンズ系においては、 下記の条件式 (2) 及び条件式 (3) を満足することが望ましい。
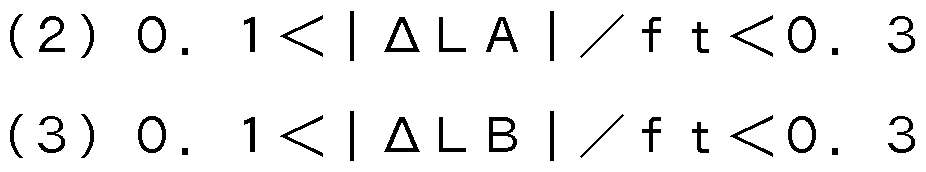
但し、 However,
△ !_八 :広角端状態から望遠端状態までの第 1 自由曲面レンズの丫軸方向に おける移動量 △ !_ Eight: Amount of movement in the vertical axis direction of the first free-form surface lens from the wide-angle end state to the telephoto end state
△ !_巳 :広角端状態から望遠端状態までの第 2自由曲面レンズの丫軸方向に おける移動量 △ !_ _: The amount of movement of the second free-form surface lens in the vertical axis direction from the wide-angle end state to the telephoto end state.
干 1 :望遠端状態におけるレンズ系全体の焦点距離 D 1: Focal length of the entire lens system in the telephoto end state
とする。 And
[0017] これにより、 丫軸方向の大きな移動スペースが必要とされないと共に非対 称な収差の発生が抑制される。 [0017] With this, a large movement space in the axial direction is not required, and the generation of asymmetric aberration is suppressed.
[0018] 第 4に、 上記した可変焦点距離レンズ系においては、 開口絞りが前記第 2 レンズユニッ ト付近に配置され、 下記の条件式 (4) を満足することが望ま しい。 [0018] Fourth, in the variable focal length lens system described above, it is desirable that the aperture stop be disposed near the second lens unit and satisfy the following conditional expression (4).

但し、 However,
△ :開口絞りから第 2レンズユニッ トまでの 軸に沿った長さの最大値 干% :広角端状態におけるレンズ系全体の焦点距離 △: Maximum length along the axis from the aperture stop to the second lens unit%: The focal length of the entire lens system in the wide-angle end state
とする。 And
[0019] これにより、 軸外光束が光軸に近い位置を通過する。 [0019] As a result, the off-axis light flux passes through a position close to the optical axis.
[0020] 第 5に、 上記した可変焦点距離レンズ系においては、 下記の条件式 (5) を満足することが望ましい。 \¥02020/174865 5 卩(:170?2019/050965 [0020] Fifth, in the variable focal length lens system described above, it is desirable to satisfy the following conditional expression (5). \\02020/174865 5 ((170?2019/050965
( 5 ) 〇. 9 <丨 △!_八 丨 /丨 △!_巳 丨 < 1 . 1 (5) 0. 9 <丨△!_8丨 / 丨△!_ 跳丨 <1.1
但し、 However,
△ !_八 :広角端状態から望遠端状態までの第 1 自由曲面レンズの丫軸方向に おける移動量 △ !_ Eight: Amount of movement in the vertical axis direction of the first free-form surface lens from the wide-angle end state to the telephoto end state
△ !_巳 :広角端状態から望遠端状態までの第 2自由曲面レンズの丫軸方向に おける移動量 △ !_ _: The amount of movement of the second free-form surface lens in the vertical axis direction from the wide-angle end state to the telephoto end state.
とする。 And
[0021 ] これにより、 二つの自由曲面レンズの移動量が小さくなる。 [0021] This reduces the amount of movement of the two free-form surface lenses.
[0022] 第 6に、 上記した可変焦点距離レンズ系においては、 前記第 1 レンズユニ ッ トは、 物体側より像側へ順に、 正の屈折力を有する第 1 レンズ群と負の屈 折力を有する第 2レンズ群とを有し、 広角端状態から望遠端状態までレンズ の位置状態が変化する際に、 前記第 1 レンズ群と前記第 2レンズ群との間隔 が増大し、 前記第 2レンズ群と前記第 2レンズユニッ トとの間隔が減少する ように、 少なくとも第 2レンズ群が光軸方向へ移動することが望ましい。 [0022] Sixthly, in the above-mentioned variable focal length lens system, the first lens unit has, in order from the object side to the image side, a negative refractive power with the first lens group having a positive refractive power. And a second lens group which has a second lens group, and when the position state of the lens changes from the wide-angle end state to the telephoto end state, the distance between the first lens group and the second lens group increases, and the second lens group It is desirable that at least the second lens unit moves in the optical axis direction so that the distance between the unit and the second lens unit decreases.
[0023] これにより、 第 1 レンズユニッ トの変倍作用が大きくなると共にズーム位 置の変化に伴う開口絞りの径の変化が抑制される。 As a result, the zooming effect of the first lens unit is increased and the change in the diameter of the aperture stop due to the change in zoom position is suppressed.
[0024] 第 7に、 上記した可変焦点距離レンズ系においては、 前記第 3レンズユニ ッ トは被写体距離に応じて光軸方向へ移動するフォーカシングレンズを含む ことが望ましい。 Seventh, in the above variable focal length lens system, it is preferable that the third lens unit includes a focusing lens that moves in the optical axis direction according to the subject distance.
[0025] これにより、 第 1 レンズユニッ トと第 2レンズユニッ トの中のレンズ群が フォーカス作用を持つ場合に、 被写体距離の変化に伴う画角の変化が生じな いようにすることが可能になる。 [0025] With this, when the lens groups in the first lens unit and the second lens unit have a focusing action, it is possible to prevent the change of the angle of view due to the change of the subject distance. become.
[0026] 第 8に、 本技術に係る撮像装置は、 可変焦点距離レンズ系と前記可変焦点 距離レンズ系によって形成された光学像を電気的信号に変換する撮像素子と を備え、 前記可変焦点距離レンズ系は、 物体側より像側へ順に、 少なくとも —つのレンズ群で構成される第 1 レンズユニッ トと、 第 1 自由曲面レンズと 第 2自由曲面レンズで構成される第 2レンズユニッ トと、 少なくとも一つの レンズ群で構成される第 3レンズユニッ トとにより構成され、 前記第 1 レン \¥02020/174865 6 卩(:170?2019/050965 Eighth, an imaging device according to an embodiment of the present technology includes a variable focal length lens system and an imaging element that converts an optical image formed by the variable focal length lens system into an electrical signal, The lens system comprises, in order from the object side to the image side, a first lens unit composed of at least one lens group, a second lens unit composed of a first free-form surface lens and a second free-form surface lens, and A third lens unit composed of at least one lens group, \¥02020/174865 6 卩 (: 170?2019/050965
ズユニッ トと前記第 3レンズユニッ トは光軸に対して回転対称な形状のレン ズで構成されると共に同じ光軸上に配置され、 前記第 1 自由曲面レンズと前 記第 2自由曲面レンズは同一形状にされ光軸に対して 1 8 0度回転して配置 され、 前記第 1 レンズユニッ トと前記第 3レンズユニッ トの光軸を 軸とし 、 像面上で 軸に垂直な軸を丫軸とし、 像面上で丫軸と 軸に垂直な軸を X 軸とすると、 前記第 1 自由曲面レンズと前記第 2自由曲面レンズは丫軸方向 へ移動可能であり、 前記第 1 自由曲面レンズと前記第 2自由曲面レンズが互 いに逆方向へ移動することにより前記第 2レンズユニッ トの屈折力が可変で あり、 焦点距離が最も短い広角端状態から焦点距離が最も長い望遠端状態ま でレンズの位置状態が変化する際に、 前記第 1 レンズユニッ トと前記第 3レ ンズユニッ トを構成するレンズ群の一部が移動するのと合わせて、 前記第 1 自由曲面レンズと前記第 2自由曲面レンズが丫軸方向へ移動するものである The unit and the third lens unit are composed of lenses that are rotationally symmetric with respect to the optical axis and are arranged on the same optical axis. They are arranged in the same shape and are rotated 180° with respect to the optical axis. The first free-form surface lens and the second free-form surface lens are movable in the direction of the lower axis, and the first free-form surface lens is movable along the axis. By moving the second free-form surface lens and the second free-form surface lens in opposite directions, the refracting power of the second lens unit can be changed. When the lens position state changes, the first free-form surface lens and the second free-form surface lens and the second lens unit that form part of the third lens unit move. Free-form surface lens moves in the vertical axis direction
[0027] これにより、 可変焦点距離レンズ系において、 第 1 自由曲面レンズと第 2 自由曲面レンズが互いに逆方向へ移動することにより第 2レンズユニッ トの 合成屈折力が変化すると共に第 1 自由曲面レンズと第 2自由曲面レンズが逆 方向へ同じ量だけ移動されることにより非対称な形状に起因する収差が第 1 自由曲面レンズと第 2自由曲面レンズの二つのレンズで互いに打ち消し合う 図面の簡単な説明 [0027] As a result, in the variable focal length lens system, the first free-form surface lens and the second free-form surface lens move in opposite directions, so that the combined refractive power of the second lens unit changes and the first free-form surface becomes Since the lens and the second free-form surface lens are moved in the opposite direction by the same amount, the aberrations caused by the asymmetrical shape cancel each other out by the two lenses, the first free-form surface lens and the second free-form surface lens. Explanation
[0028] [図 1]図 2乃至図 1 7と共に本技術の可変焦点距離レンズ系及び撮像装置の実 施の形態を示すものであり、 本図は、 可変焦点距離レンズ系の屈折力配置図 である。 [0028] [Fig. 1] Fig. 2 to Fig. 17 show an embodiment of a variable focal length lens system and an image pickup apparatus of the present technology. This diagram shows a refractive power arrangement diagram of the variable focal length lens system. Is.
[図 2]第 1実施例のレンズ構成を示す図である。 FIG. 2 is a diagram showing a lens configuration of a first example.
[図 3]第 1実施例のスポッ トダイアフラムである。 [Fig. 3] The spot diaphragm of the first embodiment.
[図 4]第 1実施例の歪曲収差図である。 FIG. 4 is a distortion diagram of the first example.
[図 5]第 2実施例のレンズ構成を示す図である。 FIG. 5 is a diagram showing a lens configuration of a second example.
[図 6]第 2実施例のスポッ トダイアフラムである。 \¥02020/174865 7 卩(:170?2019/050965 FIG. 6 is a spot diaphragm of the second embodiment. \¥02020/174865 7 卩 (: 170?2019/050965
[図 7]第 2実施例の歪曲収差図である。 FIG. 7 is a distortion diagram of the second example.
[図 8]第 3実施例のレンズ構成を示す図である。 FIG. 8 is a diagram showing a lens configuration of a third example.
[図 9]第 3実施例のスポッ トダイアフラムである。 FIG. 9 is a spot diaphragm of the third embodiment.
[図 10]第 3実施例の歪曲収差図である。 FIG. 10 is a distortion diagram of the third example.
[図 1 1]撮像装置の一例を示すブロック図である。 FIG. 11 is a block diagram showing an example of an image pickup apparatus.
[図 12]手術室システムの全体構成を概略的に示す図である。 FIG. 12 is a diagram schematically showing the overall configuration of an operating room system.
[図 13]集中操作パネルにおける操作画面の表示例を示す図である。 FIG. 13 is a diagram showing a display example of an operation screen on the centralized operation panel.
[図 14]手術室システムが適用された手術の様子の一例を示す図である。 FIG. 14 is a diagram showing an example of a state of surgery to which an operating room system is applied.
[図 15]図 1 4に示すカメラへッ ド及び〇〇 IIの機能構成の一例を示すブロッ ク図である。 [Fig. 15] Fig. 15 is a block diagram showing an example of the functional configuration of the camera head and XXII shown in Fig. 14.
[図 16]車両制御システムの概略的な構成の一例を示すブロック図である。 FIG. 16 is a block diagram showing an example of a schematic configuration of a vehicle control system.
[図 17]車外情報検出部及び撮像部の設置位置の一例を示す説明図である。 発明を実施するための形態 FIG. 17 is an explanatory diagram showing an example of installation positions of the vehicle exterior information detection unit and the imaging unit. MODE FOR CARRYING OUT THE INVENTION
[0029] 以下に、 本技術の可変焦点距離レンズ系及び撮像装置を実施するための形 態について説明する。 [0029] Hereinafter, modes for implementing the variable focal length lens system and the imaging device of the present technology will be described.
[0030] [可変焦点距離レンズ系の構成] [0030] [Configuration of variable focal length lens system]
本技術の可変焦点距離レンズ系は、 物体側より像側へ順に、 少なくとも一 つのレンズ群で構成される第 1 レンズユニッ トと、 第 1 自由曲面レンズと第 2自由曲面レンズで構成される第 2レンズユニッ トと、 少なくとも一つのレ ンズ群で構成される第 3レンズユニッ トとにより構成されている。 The varifocal lens system of this technology consists of a first lens unit consisting of at least one lens group, a first free-form surface lens and a second free-form surface lens in order from the object side to the image side. It consists of a two-lens unit and a third lens unit that is composed of at least one lens group.
[0031] また、 本技術の可変焦点距離レンズ系は、 第 1 レンズユニッ トと第 3レン ズユニッ トは光軸に対して回転対称な形状のレンズで構成されると共に同じ 光軸上に配置され、 第 1 自由曲面レンズと第 2自由曲面レンズは同一形状に され光軸に対して 1 8 0度回転して配置されている。 [0031] Further, in the variable focal length lens system of the present technology, the first lens unit and the third lens unit are composed of lenses having a rotationally symmetric shape with respect to the optical axis and are arranged on the same optical axis. The first free-form surface lens and the second free-form surface lens have the same shape and are arranged 180° rotated with respect to the optical axis.
[0032] さらに、 本技術の可変焦点距離レンズ系は、 第 1 レンズユニッ トと第 3レ ンズユニッ トの光軸を 軸とし、 像面上で 軸に垂直な軸を丫軸とし、 像面 上で丫軸と 軸に垂直な軸を乂軸とすると、 第 1 自由曲面レンズと第 2自由 曲面レンズは丫軸方向へ移動可能である。 \¥02020/174865 8 卩(:170?2019/050965 [0032] Furthermore, in the variable focal length lens system of the present technology, the optical axes of the first lens unit and the third lens unit are used as the axes, and the axis perpendicular to the axis on the image plane is the vertical axis, and on the image plane. Assuming that the vertical axis and the axis perpendicular to the axis are horizontal axes, the first free-form surface lens and the second free-form surface lens can move in the vertical axis direction. \¥02020/174865 8 卩 (: 170?2019/050965
[0033] 加えて、 本技術の可変焦点距離レンズ系は、 第 1 自由曲面レンズと第 2自 由曲面レンズが互いに逆方向へ移動することにより第 2レンズユニッ トの屈 折力が可変であり、 焦点距離が最も短い広角端状態から焦点距離が最も長い 望遠端状態までレンズの位置状態が変化する際に、 第 1 レンズユニッ トと第 3レンズユニッ トを構成するレンズ群の一部が移動するのと合わせて、 第 1 自由曲面レンズと第 2自由曲面レンズが丫軸方向へ移動する。 [0033] In addition, in the variable focal length lens system of the present technology, the first free-form surface lens and the second free-form surface lens move in opposite directions, so that the bending force of the second lens unit is variable. , When the lens position changes from the wide-angle end state with the shortest focal length to the telephoto end state with the longest focal length, part of the lens groups that make up the first lens unit and the third lens unit moves. At the same time, the first free-form surface lens and the second free-form surface lens move in the axial direction.
[0034] —般的なズームレンズでは球面レンズや非球面レンズと言った回転対称な 形状のレンズが使用され、 少なくとも二つの可動レンズ群が光軸方向へ移動 する構成である。 In a general zoom lens, rotationally symmetric lenses such as spherical lenses and aspherical lenses are used, and at least two movable lens groups are configured to move in the optical axis direction.
[0035] 具体的には、 一方の可動レンズ群が移動し、 それに伴う像面位置の変化を 他のレンズ群が補償するように移動する。 [0035] Specifically, one movable lens group moves, and the other lens group moves so as to compensate the change in the image plane position due to the movement.
[0036] 一方、 特開 2 0 0 7 _ 4 0 6 3号公報等で開示される可変焦点距離レンズ 系では、 4枚の自由曲面レンズが配置され、 いずれもが光軸に垂直な方向へ 移動可能であった。 そして、 物体側に配置される 2枚の自由曲面レンズが互 いに逆向きに移動することにより、 レンズ系全体の屈折力を変化させ、 それ に伴う像面位置の変化を像側に配置される 2枚の自由曲面レンズが互いに逆 向きに移動することにより補償していた。 On the other hand, in the variable focal length lens system disclosed in Japanese Patent Application Laid-Open No. 2000_4_063, etc., four free-form surface lenses are arranged, and all of them are arranged in a direction perpendicular to the optical axis. It was movable. Then, the two free-form lenses arranged on the object side move in opposite directions to each other, thereby changing the refracting power of the entire lens system, and the resulting change in the image plane position is arranged on the image side. The two free-form lenses, which are the same, move in opposite directions to compensate.
[0037] ここで、 本技術においては、 回転非対称のレンズを用いているため、 X V 軸を定義する。 回転対称な形状のレンズで構成される第 1 レンズユニッ ト と第 3レンズユニッ トの光軸を 軸とし、 像面上で 軸に垂直な面を丫軸と し、 像面上で 軸と丫軸に垂直な軸を乂軸として、 像面上の原点で 3つの軸 が交わる。 [0037] Here, in the present technology, since a rotationally asymmetric lens is used, the XV axis is defined. The optical axes of the first lens unit and the third lens unit, which are composed of rotationally symmetric lenses, are the axes, and the plane perpendicular to the axis on the image plane is the axis and the axis and the axis on the image plane are the axes. With the axis perpendicular to the axis as the main axis, the three axes intersect at the origin on the image plane.
[0038] 本技術の可変焦点距離レンズ系は第 1 自由曲面レンズと第 2自由曲面レン ズが同じ形状で 軸に対して 1 8 0度回転されて配置される。 そして、 第 1 自由曲面レンズと第 2自由曲面レンズが互いに逆方向へ移動することで、 第 2レンズユニッ トの合成屈折力が変化する。 これと一般的なズームレンズと を組合せることで、 像面位置を一定に保ちながら光学全長を短縮化する。 [0038] In the variable focal length lens system of the present technology, the first free-form surface lens and the second free-form surface lens have the same shape and are arranged by rotating 180 degrees about the axis. Then, the combined refracting power of the second lens unit changes as the first free-form surface lens and the second free-form surface lens move in opposite directions. By combining this with a general zoom lens, the total optical length can be shortened while keeping the image plane position constant.
[0039] 従来のズームレンズは各レンズ群の移動方向が光軸方向のみであったのに \¥02020/174865 9 卩(:170?2019/050965 In the conventional zoom lens, the moving direction of each lens group is only the optical axis direction. \¥02020/174865 9 boxes (: 170?2019/050965
対して、 本技術の可変焦点距離レンズ系は二つの自由曲面レンズを光軸方向 以外に移動させることで焦点距離を変化させる自由度を増やしている。 In contrast, the variable focal length lens system of the present technology increases the degree of freedom for changing the focal length by moving the two free-form surface lenses in directions other than the optical axis direction.
[0040] 特に、 第 1 自由曲面レンズと第 2自由曲面レンズを同一形状とすることで 、 自由曲面の形状が滑らかになり、 停止位置のズレや自由曲面の偏心 (物体 側と像側のレンズ面同士の倒れや移動) による性能低下を防ぐことを可能と した。 [0040] In particular, by making the first free-form surface lens and the second free-form surface lens have the same shape, the shape of the free-form surface becomes smooth, and the shift of the stop position and the eccentricity of the free-form surface (lens on the object side and the image side) It has become possible to prevent performance deterioration due to the surfaces collapsing or moving.
[0041 ] また、 焦点距離を変化させる際に、 第 1 自由曲面レンズと第 2自由曲面レ ンズを逆方向へ同じ量だけ移動させることで、 非対称な形状に起因する収差 を第 1 自由曲面レンズと第 2自由曲面レンズの二つのレンズで互いに打ち消 して、 良好な光学性能を実現した。 [0041] Further, when changing the focal length, by moving the first free-form surface lens and the second free-form surface lens in the opposite directions by the same amount, the aberrations caused by the asymmetrical shape can be eliminated. The two lenses, the second free-form surface lens and the second free-form surface, cancel each other out to achieve good optical performance.
[0042] 上記のように、 本技術の可変焦点距離レンズ系は、 各種の効果を奏し、 小 型で高倍率な可変焦点距離レンズ系を提供することができる。 [0042] As described above, the variable focal length lens system of the present technology has various effects, and can provide a small-sized and high-magnification variable focal length lens system.
[0043] 本技術の可変焦点距離レンズ系では、 焦点距離を変化させる変倍作用が従 来のズームレンズと自由曲面レンズを移動させることの組合せによって生じ るようにされている。 [0043] In the variable focal length lens system of the present technology, the zooming effect of changing the focal length is caused by the combination of moving the conventional zoom lens and the free-form surface lens.
[0044] この時、 自由曲面レンズの屈折力が移動量に応じて大きく変化すれば、 焦 点距離を変化させる効果が大きくなるが、 色収差の発生を抑えることが難し いため、 所定の光学性能を得ることができない。 [0044] At this time, if the refractive power of the free-form surface lens largely changes in accordance with the amount of movement, the effect of changing the focal length becomes large, but it is difficult to suppress the occurrence of chromatic aberration, so that it is possible to obtain a predetermined optical performance. Can't get
[0045] そこで、 本技術の可変焦点距離レンズ系では、 下記の条件式 (1) を満足 することが望ましい。 Therefore, in the variable focal length lens system of the present technology, it is desirable that the following conditional expression (1) is satisfied.
(1) 0 . 0 3 <八 2/å<0. 3 5 (1) 0.0 3 <8 2/å <0.3 5
但し、 However,
△ 2 : ø 27/¢ 2 △ 2: ø 27/¢ 2
¢27 :望遠端状態における第 2レンズユニッ トの屈折力 ¢27: Refracting power of the 2nd lens unit in the telephoto end state
0 :広角端状態における第 2レンズユニッ トの屈折力 0: Refracting power of the second lens unit in the wide-angle end state
å : 干 1: /干 å: dried 1: / dried
干 1 :望遠端状態におけるレンズ系全体の焦点距離 D 1: Focal length of the entire lens system in the telephoto end state
干% :広角端状態におけるレンズ系全体の焦点距離 \¥0 2020/174865 10 卩(:170?2019/050965 %: Focal length of the entire lens system in the wide-angle end state \¥0 2020/174865 10 box (: 170?2019/050965
とする。 And
[0046] 条件式 (1) は、 レンズ系全体のズーム比に対する第 2レンズユニッ トが 占める割合を規定する条件式である。 Conditional expression (1) is a conditional expression that defines the ratio of the second lens unit to the zoom ratio of the entire lens system.
[0047] 条件式 (1) の上限値を上回った場合には、 望遠端状態で発生する色収差 が大きくなってしまい、 光学性能が低下してしまう。 If the upper limit of conditional expression (1) is exceeded, the chromatic aberration that occurs in the telephoto end state becomes large and the optical performance deteriorates.
[0048] 逆に、 条件式 (1) の下限値を下回った場合には、 従来のズームレンズか らの小型化が充分に図れなくなってしまう。 On the contrary, when the value goes below the lower limit of the conditional expression (1), downsizing of the conventional zoom lens cannot be achieved sufficiently.
[0049] 従って、 可変焦点距離レンズ系が条件式 (1) を満足することにより、 望 遠端状態での色収差の発生を抑制して光学性能の向上を図ることができると 共に小型化を図ることができる。 Therefore, by satisfying the conditional expression (1) in the variable focal length lens system, it is possible to suppress the occurrence of chromatic aberration in the telephoto end state to improve the optical performance, and also to reduce the size. be able to.
[0050] 尚、 本技術において更なる高性能化を実現するには、 条件式 (1) の上限 値を〇. 3とすることが望ましい。 [0050] In order to further improve the performance of the present technology, it is desirable to set the upper limit of conditional expression (1) to 0.3.
[0051 ] 更に、 本技術では下記の条件式 (2) 及び条件式 (3) を満足することに より、 小型化と高性能化のバランス化を図ることができる。
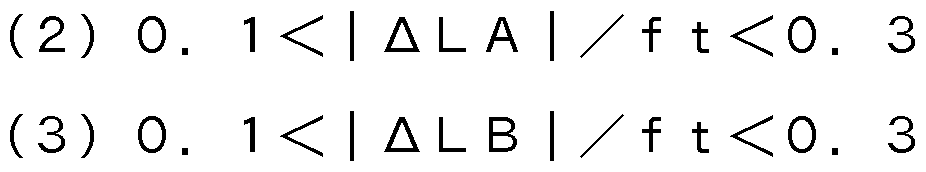
但し、 However,
△ !_八 :広角端状態から望遠端状態までの第 1 自由曲面レンズの丫軸方向に おける移動量 △ !_ Eight: Amount of movement in the vertical axis direction of the first free-form surface lens from the wide-angle end state to the telephoto end state
△ !_巳 :広角端状態から望遠端状態までの第 2自由曲面レンズの丫軸方向に おける移動量 △ !_ _: The amount of movement of the second free-form surface lens in the vertical axis direction from the wide-angle end state to the telephoto end state.
干 1 :望遠端状態におけるレンズ系全体の焦点距離 D 1: Focal length of the entire lens system in the telephoto end state
とする。 And
[0052] 条件式 (2) と条件式 (3) は、 第 1 自由曲面レンズと第 2自由曲面レン ズの移動量を規定する条件式である。 条件式 (2) と条件式 (3) に含まれ る干 1は、 広角端状態におけるレンズ系全体の焦点距離を干 とし、 望遠端 状態と広角端状態におけるレンズ系全体の変倍比を とするときに、 チ% という意味である。 チ%は基準となる広角端状態における焦点距離で条件 \¥0 2020/174865 1 1 卩(:170?2019/050965 [0052] Conditional expressions (2) and (3) are conditional expressions that regulate the movement amounts of the first free-form surface lens and the second free-form surface lens. Condition 1 included in Conditional Expressions (2) and (3) sets the focal length of the entire lens system in the wide-angle end state to the maximum zoom ratio in the telephoto end state and the wide-angle end state. When you do, it means that you are %. J% is the focal length in the wide-angle end state, which is the reference \\0 2020/174865 1 1 卩 (: 170?2019/050965
式をノーマライズ (無次元化) する意味で含まれており、 結果的に、 条件式 (2) と条件式 (3) は変倍比に対する第 1 自由曲面レンズと第 2自由曲面 レンズの移動量を最適化することになる。 It is included in the meaning of normalizing the equation, and as a result, the conditional expressions (2) and (3) are the movement amounts of the first free-form surface lens and the second free-form surface lens with respect to the zoom ratio. Will be optimized.
[0053] 条件式 (2) と条件式 (3) の上限値を上回った場合には、 丫軸方向の大 きな移動スぺースが必要となり、 鏡筒サイズが大きくなってしまう。 If the upper limits of conditional expressions (2) and (3) are exceeded, a large movement space in the vertical axis direction is required, and the lens barrel size becomes large.
[0054] 条件式 (2) と条件式 (3) の下限値を下回った場合には、 少ない移動量 で形状が大きく変化するために、 非対称な収差が大きく発生してしまう。 If the lower limits of conditional expressions (2) and (3) are exceeded, the shape will change significantly with a small amount of movement, and a large amount of asymmetric aberration will occur.
[0055] 従って、 可変焦点距離レンズ系が条件式 (2) 及び条件式 (3) を満足す ることにより、 第 1 自由曲面レンズと第 2自由曲面レンズの丫軸方向におけ る移動スぺースを小さく して鏡筒サイズの小型化を図ることができると共に 第 1 自由曲面レンズと第 2自由曲面レンズの移動に伴う非対称な収差の発生 を抑制することができる。 Therefore, if the variable focal length lens system satisfies the conditional expressions (2) and (3), the moving space in the vertical axis direction of the first free-form surface lens and the second free-form surface lens can be improved. It is possible to reduce the size of the lens barrel and reduce the size of the lens barrel, and it is possible to suppress the occurrence of asymmetrical aberrations due to the movement of the first free-form surface lens and the second free-form surface lens.
[0056] 本技術においては、 更なる高性能化を図るために、 開口絞りが第 2レンズ ユニッ ト付近に配置され、 下記の条件式 (4) を満足することが望ましい。

但し、 However,
△ :開口絞りから第 2レンズユニッ トまでの 軸に沿った長さの最大値 干% :広角端状態におけるレンズ系全体の焦点距離 △: Maximum value along the axis from the aperture stop to the second lens unit%: The focal length of the entire lens system in the wide-angle end state
とする。 And
[0057] 第 1 自由曲面レンズと第 2自由曲面レンズは開口絞りからの距離が異なる ため、 非対称な軸外収差が発生し易い。 従って、 第 1 自由曲面レンズと第 2 自由曲面レンズを開口絞り付近に配置することによって、 軸外光束が光軸に 近い位置を通過するため、 非対称な軸外収差を抑えることが可能である。 Since the first free-form surface lens and the second free-form surface lens have different distances from the aperture stop, asymmetric off-axis aberrations are likely to occur. Therefore, by arranging the first free-form surface lens and the second free-form surface lens in the vicinity of the aperture stop, the off-axis light beam passes through a position close to the optical axis, and asymmetric off-axis aberrations can be suppressed.
[0058] 特に、 条件式 (4) を満足するように第 2レンズユニッ トと開口絞りを配 置することで、 高性能化を図ることができる。 [0058] In particular, by disposing the second lens unit and the aperture stop so as to satisfy the conditional expression (4), high performance can be achieved.
[0059] 尚、 本技術において、 自由曲面レンズでの大きさを小型化し、 レンズ系全 体を小型化する場合には、 条件式 (4) の上限値を〇. 6とすることが望ま しい。 \¥0 2020/174865 12 卩(:170?2019/050965 [0059] In the present technology, in order to reduce the size of the free-form surface lens and the lens system as a whole, it is desirable to set the upper limit of conditional expression (4) to 0.6. .. \¥0 2020/174865 12 (: 170?2019/050965
[0060] 本技術においては、 二つの自由曲面レンズの停止位置精度を緩めて、 製造 時にも優れた光学性能を得るために、 下記の条件式 (5) を満足することが 望ましい。 [0060] In the present technology, it is desirable to satisfy the following conditional expression (5) in order to loosen the stop position accuracy of the two free-form surface lenses and obtain excellent optical performance during manufacturing.
(5) 〇. 9 <丨 △!_八 丨 /丨 △!_巳 丨 < 1 . 1 (5) ○ 9.9 <丨△!_ eight 丨 / 丨△!_ 巳丨 <1.1
但し、 However,
△ !_八 :広角端状態から望遠端状態までの第 1 自由曲面レンズの丫軸方向に おける移動量 △ !_ Eight: Amount of movement in the vertical axis direction of the first free-form surface lens from the wide-angle end state to the telephoto end state
△ !_巳 :広角端状態から望遠端状態までの第 2自由曲面レンズの丫軸方向に おける移動量 △ !_ _: The amount of movement of the second free-form surface lens in the vertical axis direction from the wide-angle end state to the telephoto end state.
とする。 And
[0061 ] 本技術においては、 二つの自由曲面レンズが同一の形状であるため、 移動 量丨 △!_ 丨 と 丨 △!_巳 丨が大きく異なると、 一つのレンズ面での作用が異 なってしまう。 [0061] In the present technology, since the two free-form lenses have the same shape, if the movement amount ∆! Will end up.
[0062] 従って、 可変焦点距離レンズ系が条件式 (5) を満足することにより、 二 つの自由曲面レンズの移動量が小さくなり、 光学性能の向上を図ることがで きる。 Therefore, when the variable focal length lens system satisfies the conditional expression (5), the moving amounts of the two free-form surface lenses are reduced, and the optical performance can be improved.
[0063] また、 更なる高い光学性能を実現するには、 条件式 (5) の上限値を 1 . [0063] Further, in order to achieve higher optical performance, the upper limit of conditional expression (5) should be 1.
0 5とするか、 下限値を〇. 9 5とすることが望ましい。 It is desirable to set it to 05 or the lower limit to 0.95.
[0064] 本技術においては、 更なる高性能化を図るために、 第 1 レンズユニッ トは 、 物体側より像側へ順に、 正の屈折力を有する第 1 レンズ群と負の屈折力を 有する第 2レンズ群とを有し、 広角端状態から望遠端状態までレンズの位置 状態が変化する際に、 第 1 レンズ群と第 2レンズ群との間隔が増大し、 第 2 レンズ群と第 2レンズユニッ トとの間隔が減少するように、 少なくとも第 2 レンズ群が光軸方向へ移動することが望ましい。 [0064] In the present technology, in order to further improve performance, the first lens unit has, in order from the object side to the image side, the first lens group having positive refractive power and the negative lens power. The second lens group, and when the lens position state changes from the wide-angle end state to the telephoto end state, the distance between the first lens group and the second lens group increases, and the second lens group and the second lens group It is desirable that at least the second lens unit moves in the optical axis direction so that the distance to the lens unit decreases.
[0065] こうした構成にすることにより、 第 1 レンズユニッ トの変倍作用を大きく し、 ズーム位置の変化に伴う開口絞りの径の変化を抑えている。 その結果、 広角端状態と望遠端状態で必要になる自由曲面レンズの面精度が均等になる ようにして、 量産時にも安定した光学品質を得ることができる。 \¥0 2020/174865 13 卩(:170?2019/050965 With such a configuration, the zooming action of the first lens unit is increased, and the change in the diameter of the aperture stop due to the change in zoom position is suppressed. As a result, the surface precision of the free-form surface lens required in the wide-angle end state and the telephoto end state is equalized, and stable optical quality can be obtained even during mass production. \\0 2020/174865 13 卩 (: 170?2019/050965
[0066] 本技術においては、 第 3レンズユニッ トは被写体距離に応じて光軸方向へ 移動するフォーカシングレンズを含むことが望ましい。 In the present technology, it is desirable that the third lens unit include a focusing lens that moves in the optical axis direction according to the subject distance.
[0067] これは第 1 レンズユニッ トと第 2レンズユニッ トが変倍作用を持つために 、 この中のレンズ群がフォーカス作用を持つ場合には、 レンズ系全体の焦点 距離が変化して、 被写体距離の変化に伴って画角が変化してしまうからであ る。 [0067] This is because the first lens unit and the second lens unit have a zooming action. Therefore, when the lens group in these has a focusing action, the focal length of the entire lens system changes, This is because the angle of view changes as the subject distance changes.
[0068] 従って、 第 3レンズユニッ トがフォーカシングレンズを含むことにより、 第 1 レンズユニッ トと第 2レンズユニッ トの中のレンズ群がフォーカス作用 を持つ場合に、 被写体距離の変化に伴う画角の変化を生じないようにして、 光学性能の向上を図ることが可能になる。 [0068] Therefore, when the third lens unit includes the focusing lens, when the lens groups in the first lens unit and the second lens unit have a focusing action, the angle of view depending on the change in the subject distance is increased. It is possible to improve the optical performance by avoiding the change of.
[0069] 尚、 本技術による各実施例では第 2レンズユニッ トの像側に開口絞りを配 置しているが、 開口絞りは、 第 2レンズユニッ トの物体側や第 2レンズユニ ッ トを構成する 2枚の自由曲面レンズの間に配置することも可能である。 [0069] In each of the embodiments according to the present technology, the aperture stop is arranged on the image side of the second lens unit, but the aperture stop is located on the object side of the second lens unit or the second lens unit. It is also possible to place it between the two free-form lenses that compose it.
[0070] 本技術の可変焦点距離では、 自由曲面の形状を X V多項式で表現する。 具 体的に形状を示す式は、 !<をコーニック係数 (円錐定数) 、 0 3、 0 4、 -、 〇 5 3を係数とすると、 軸方向のサグ量 3 3 9が以下の数式 1で される。 [0070] With the variable focal length of the present technology, the shape of the free-form surface is represented by an XV polynomial. The formula that shows the concrete shape is! <A conic coefficient (conic constant), 0 3, 0 4, -, when the 〇 5 3 coefficients, sag 3 3 9 in the axial direction is in Equation 1 below.
[0071 ] [数 1 ]

[0072] 本技術においては、 第 1 自由曲面レンズと第 2自由曲面レンズを丫軸方向 に移動させるため、 第 1 自由曲面レンズと第 2自由曲面レンズは丫_ 平面 に対して対称な形状である。 具体的には、 Xの奇数次項はゼロという意味で ある。 [0072] In the present technology, since the first free-form surface lens and the second free-form surface lens are moved in the axial direction, the first free-form surface lens and the second free-form surface lens have a symmetrical shape with respect to the flat plane. is there. Specifically, the odd-numbered terms of X mean zero.
[0073] また、 第 1 自由曲面レンズと第 2自由曲面レンズは 軸を基準に反対向き に配置されるため、 乂丫多項式としては丫が奇数次となる項の符号が逆向き になる。 \¥02020/174865 14 卩(:170?2019/050965 [0073] Further, since the first free-form surface lens and the second free-form surface lens are arranged in opposite directions with respect to the axis, the signs of the odd polynomial terms of the polynomials are opposite. \¥02020/174865 14 卩 (: 170?2019/050965
[0074] 尚、 本技術においては、 レンズ系の像側にモアレ縞の発生を防ぐために口 —パスフィルタを配置したり、 受光素子の分光感度特性に応じて赤外カッ ト フィルタを配置することも勿論可能である。 [0074] In the present technology, a mouth-pass filter is arranged on the image side of the lens system to prevent the generation of moire fringes, and an infrared cut filter is arranged according to the spectral sensitivity characteristics of the light receiving element. Of course, it is possible.
[0075] [可変焦点距離レンズ系の数値実施例] [Numerical Example of Variable Focal Length Lens System]
以下に、 本技術の可変焦点距離レンズ系の具体的な実施の形態及び実施の 形態に具体的な数値を適用した数値実施例について、 図面及び表を参照して 説明する。 Hereinafter, specific embodiments of the variable focal length lens system of the present technology and numerical examples in which specific numerical values are applied to the embodiments will be described with reference to the drawings and tables.
[0076] 図 1は、 本技術の各実施例による可変焦点距離レンズ系の屈折力配置を示 している。 本技術の可変焦点距離レンズ系は、 物体側より像側へ順に、 第 1 レンズユニット II 1 と第 2レンズユニット II 2と第 3レンズユニット II 3が 配置されている。 [0076] FIG. 1 illustrates a refractive power arrangement of a variable focal length lens system according to each embodiment of the present technology. In the variable focal length lens system of this technology, the first lens unit II 1, the second lens unit II 2 and the third lens unit II 3 are arranged in order from the object side to the image side.
[0077] 第 1 レンズユニッ ト II 1は正の屈折力を有する第 1 レンズ群〇 1 と負の屈 折力を有する第 2レンズ群◦ 2とで構成されている。 第 2レンズユニッ ト II 2は自由曲面レンズによる第 3レンズ群 0 3と第 4レンズ群 0 4とにより構 成されている。 第 3レンズユニッ ト II 3は第 5レンズ群◦ 5と第 6レンズ群 ◦ 6と第 7レンズ群◦ 7と第 8レンズ群◦ 8で構成されている。 The first lens unit II 1 is composed of the first lens group O 1 having a positive refractive power and the second lens group O 2 having a negative refractive power. The second lens unit II 2 is composed of a third lens group 0 3 and a fourth lens group 0 4 which are free-form lenses. The third lens unit II 3 is composed of the fifth lens group ◦ 5, the sixth lens group ◦ 6, the seventh lens group ◦ 7, and the eighth lens group ◦ 8.
[0078] 焦点距離が最も短くなる広角端状態から最も長くなる望遠端状態まで焦点 距離状態が変化する際に、 第 1 レンズ群〇 1は固定され、 第 2レンズ群 0 2 は 軸に沿って像側へ移動し、 第 3レンズ群◦ 3は丫軸方向におけるマイナ ス方向へ移動し、 第 4レンズ群◦ 4は丫軸方向におけるプラス方向へ移動し 、 第 5レンズ群 0 5は 軸に沿って物体側へ移動し、 第 6レンズ群 0 6は 軸に沿って物体側へ移動し、 第 7レンズ群 0 7は 軸に沿って物体側へ移動 し、 第 8レンズ群◦ 8は固定される。 [0078] When the focal length state changes from the wide-angle end state in which the focal length is the shortest to the telephoto end state in which the focal length is the longest, the first lens group 0 1 is fixed, and the second lens group 0 2 is along the axis. Moving to the image side, the third lens group ◦ 3 moves in the minor direction in the vertical axis direction, the fourth lens group ◦ 4 moves in the positive direction in the vertical axis direction, and the fifth lens group 0 5 moves in the axial direction. Along the axis, the 6th lens group 0 6 moves to the object side, the 7th lens group 0 7 moves to the object side along the axis, and the 8th lens group ◦ 8 is fixed. To be done.
[0079] そして、 第 1 レンズ群〇 1 と第 2レンズ群◦ 2との空気間隔 0 1は増大し 、 第 2レンズ群◦ 2と第 3レンズ群◦ 3との空気間隔 0 2は減少し、 第 4レ ンズ群◦ 4と第 5レンズ群◦ 5との空気間隔口 4は減少し、 第 5レンズ群◦ 5と第 6レンズ群◦ 6との空気間隔 0 5は変化し、 第 6レンズ群◦ 6と第 7 レンズ群◦ 7との空気間隔口 6は変化し、 第 7レンズ群◦ 7と第 8レンズ群 \¥02020/174865 15 卩(:170?2019/050965 [0079] Then, the air distance 0 1 between the first lens group 〇 1 and the second lens group ◦ 2 increases, and the air distance 0 2 between the second lens group ◦ 2 and the third lens group ◦ 3 decreases. , The 4th lens group ◦ 4 and the 5th lens group ◦ 5 the air gap port 4 decreases, the 5th lens group ◦ 5 and the 6th lens group ◦ 6 the air gap 0 5 changes, The air gap 6 between the lens group ◦ 6 and the 7th lens group ◦ 7 changed, and the 7th lens group ◦ 7 and the 8th lens group \¥02020/174865 15 卩 (: 170?2019/050965
0 8との空気間隔 0 7は増大する。 The air gap 07 with 08 is increased.
[0080] 開口絞り 3は第 4レンズ群 0 4の像側に配置され、 焦点距離が変化する際 に光軸方向に固定される。 The aperture stop 3 is arranged on the image side of the fourth lens group 04, and is fixed in the optical axis direction when the focal length changes.
[0081 ] 本技術による各実施例では第 8レンズ群◦ 8の像側に、 丨 [¾カッ トフィル 夕一、 口ーパスフィルター、 イメージセンサーのカバーガラスが配置されて いる。 In each of the embodiments according to the present technology, the image pickup side of the eighth lens group 8 is provided with a rear cover filter, a mouth-pass filter, and a cover glass for an image sensor.
[0082] 各実施例において、 非球面は以下の数式で表される。 [0082] In each example, the aspherical surface is represented by the following mathematical formula.
[0083] [数 2] z = cH2y [ 1 + [1- (1 +0 c^H2} 1 /2] +八1~14 +巳1~16+ [0083] [Numeric 2] z = cH 2 y [1 + [1- (1 +0 c ^ H 2 } 1 / 2 ] + eight 1 to 1 4 + Mitsu 1 to 16 +
㈩ 2 =(>(2 + ) 1 /2) ㈩ 2 = (> ( 2 + ) 1/2)
[0084] 尚、 1~1は光軸からの距離、 2はサグ量、 〇は曲率、 1<はコーニック係数 ( 円錐定数) 、 八、 巳、 は非球面係数である。 It should be noted that 1 to 1 are distances from the optical axis, 2 is sag amount, ◯ is curvature, 1< is conic coefficient (conical constant), 8, and are aspherical coefficients.
[0085] <第 1実施例> <First Example>
図 2は、 本技術の第 1実施例に係る可変焦点距離レンズ系 1のレンズ断面 図を示す。 FIG. 2 shows a lens cross-sectional view of a variable focal length lens system 1 according to the first example of the present technology.
[0086] 第 1 レンズ群◦ 1は、 像側に凹面を向けたメニスカス形状の負レンズと物 体側に凸面を向けた正レンズとの接合レンズ !_ 1 1 と、 物体側に凸面を向け たメニスカス形状の正レンズ !_ 1 2とで構成される。 [0086] The first lens group ◦ 1 has a cemented lens !_ 1 1 consisting of a negative meniscus lens having a concave surface facing the image side and a positive lens having a convex surface facing the object side, and a convex surface facing the object side. It consists of a meniscus-shaped positive lens !_ 1 2.
[0087] 第 2レンズ群 0 2は、 物体側に凸面を向けたメニスカス形状の負レンズ !_ The second lens group 02 is a meniscus-shaped negative lens whose convex surface faces the object side!
2 1 と、 両凹レンズと両凸レンズとの接合レンズ !_ 2 2と、 物体側に凹面を 向けた負レンズ !_ 2 3とで構成される。 It consists of 2 1, a cemented lens !_ 2 2 composed of a biconcave lens and a biconvex lens, and a negative lens !_ 2 3 with the concave surface facing the object side.
[0088] 第 3レンズ群 0 3は、 1枚の第 1 自由曲面レンズ !_ 3で構成され、 第 4レ ンズ群 0 4は 1枚の第 2自由曲面レンズ !_ 4で構成され、 第 1 自由曲面レン ズ !_ 3と第 2自由曲面レンズ !_ 4は 軸に対して反転した状態で配置される [0088] The third lens group 0 3 is composed of one first free-form surface lens !_ 3, and the fourth lens group 0 4 is composed of one second free-form surface lens !_ 4. 1 Free-form surface lens !_ 3 and 2nd free-form surface lens !_ 4 are arranged with their axes inverted.
[0089] 第 5レンズ群 0 5は、 両凸形状の正レンズ !_ 5 1 と、 物体側に凸面を向け た正レンズと像側に凹面を向けた負レンズとの接合レンズ !_ 5 2とで構成さ れる。 \¥02020/174865 16 卩(:170?2019/050965 [0089] The fifth lens group 0 5 is a cemented lens of a biconvex positive lens !_ 5 1 and a positive lens with a convex surface facing the object side and a negative lens with a concave surface facing the image side !_ 5 2 It consists of and. \¥02020/174865 16 卩(: 170?2019/050965
[0090] 第 6レンズ群◦ 6は両凸形状の正レンズ!- 6で構成される。 [0090] 6th lens group ◦ 6 is a positive biconvex lens! -Composed of 6.
[0091 ] 第 7レンズ群◦ 7は像側に凹面を向けた負レンズ !_ 7で構成される。 [0091] The seventh lens group ◦ 7 is composed of a negative lens !_ 7 having a concave surface facing the image side.
[0092] 第 8レンズ群 0 8は物体側に凸面を向けた正レンズ !_ 8で構成される。 The eighth lens group 08 is composed of a positive lens !_ 8 having a convex surface directed toward the object side.
[0093] 尚、 第 1実施例においては、 第 1 自由曲面レンズ !_ 3と第 2自由曲面レン ズ!_ 4の丫軸方向における移動量が僅かに相違する。 これにより、 可変焦点 距離レンズ系 1の丫軸方向における小型化を図ることが可能になる。 In the first example, the movement amounts of the first free-form surface lens !_ 3 and the second free-form surface lens !_ 4 in the vertical axis direction are slightly different. This makes it possible to reduce the size of the variable focal length lens system 1 in the vertical axis direction.
[0094] 以下の表 1〜表 4に本技術における第 1実施例の諸元の値を示す。 表 1 に は各レンズの曲率半径等のレンズデータを示し、 表 2には焦点距離を変化さ せる際の可変間隔と移動量 (ズーム変位量) を示し、 表 3には自由曲面レン ズの形状を表す X V自由曲面係数 (X V多項式係数) 、 表 4には非球面係数 を示す。 [0094] Tables 1 to 4 below show values of specifications of the first embodiment of the present technology. Table 1 shows the lens data such as the radius of curvature of each lens, Table 2 shows the variable distance and movement amount (zoom displacement amount) when changing the focal length, and Table 3 shows the free-form lens range. The XV free-form surface coefficients (XV polynomial coefficients) that represent the shape, and Table 4 show the aspherical surface coefficients.
[0095] 尚、 以下の各表や説明において示した記号の意味等については、 下記に示 す通りである。 [0095] The meanings of the symbols shown in the following tables and explanations are as shown below.
[0096] 表 1 において、 「曲率半径」 は曲率の逆数を示し、 「曲率半径」 において 「0」 は平面を示し、 「口 11」 は第 番目の面と第 + 1番目の面の間の可 変間隔である軸上面間隔 (レンズの中心の厚み又は空気間隔) を示し、 「屈 折率」 と 「アッベ数」 は 線 (ス = 5 8 7 . 6 n m) における屈折率とアッ ベ数を示す。 表 2において、 「X」 、 「ソ」 はそれぞれ X軸方向と丫軸方向 における各値を示し、 「丫シフト量」 は第 1 自由曲面レンズ !_ 3と第 2自由 曲面レンズ 1- 4の丫軸方向における移動量を示す。 [0096] In Table 1, "radius of curvature" indicates the reciprocal of curvature, "0" in "radius of curvature" indicates a plane, and "mouth 11" between the 1st and +1st surfaces. Shows the axial spacing (the thickness of the center of the lens or the air spacing) that is a variable spacing. The “refractive index” and “Abbe number” are the refractive index and Abbe number at the line (s = 5 87.6 nm). Indicates. In Table 2, “X” and “S” indicate the values in the X-axis direction and the vertical axis direction, respectively, and the “shift amount” is for the first free-form surface lens !_ 3 and the second free-form surface lens 1-4. Indicates the amount of movement in the vertical axis direction.
[0097] [0097]
\¥02020/174865 17 卩(:17 2019/050965\¥02020/174865 17 卩(: 17 2019/050965
[表 1][table 1]

[0098] [表 2][0098] [Table 2]

[0099] [0099]
\¥0 2020/174865 19 卩(:17 2019/050965\¥0 2020/174865 19 卩(: 17 2019/050965
[表 3][Table 3]

[0100] [0100]
\¥02020/174865 20 卩(:17 2019/050965\¥02020/174865 20 units (: 17 2019/050965
[表 4][Table 4]

[0101] 表 5に第 1実施例における条件式の対応値を示す。 [0101] Table 5 shows the corresponding values of the conditional expressions in the first embodiment.
[0102] [0102]
\¥0 2020/174865 21 卩(:170?2019/050965 \¥0 2020/174865 21 卩 (: 170?2019/050965
[表 5] [Table 5]

[0103] 図 3には第 1実施例の広角端状態と望遠端状態におけるスポッ トダイヤグ ラムを示し、 図 4には第 1実施例の歪曲収差図を示す。 [0103] Fig. 3 shows the spot diagram of the first embodiment in the wide-angle end state and the telephoto end state, and Fig. 4 shows the distortion diagram of the first embodiment.
[0104] 各収差図から、 本実施例は諸収差が良好に補正され、 優れた結像性能を有 していることが明らかである。 From each aberration diagram, it is apparent that various aberrations are satisfactorily corrected and that this example has excellent imaging performance.
[0105] <第 2実施例> <Second Example>
図 5は、 本技術の第 2実施例に係る可変焦点距離レンズ系 2のレンズ断面 図を示す。 FIG. 5 shows a lens cross-sectional view of a variable focal length lens system 2 according to the second example of the present technology.
[0106] 第 1 レンズ群◦ 1は、 像側に凹面を向けたメニスカス形状の負レンズと物 体側に凸面を向けた正レンズとの接合レンズ !_ 1 1 と、 物体側に凸面を向け たメニスカス形状の正レンズ !_ 1 2とで構成される。 [0106] The first lens group ◦ 1 consists of a cemented lens !_ 1 1 consisting of a negative meniscus lens with a concave surface facing the image side and a positive lens with a convex surface facing the object side, and a convex surface facing the object side. It consists of a meniscus-shaped positive lens !_ 1 2.
[0107] 第 2レンズ群 0 2は、 物体側に凸面を向けたメニスカス形状の負レンズ !_ [0107] The second lens group 0 2 is a negative meniscus lens whose convex surface faces the object side!
2 1 と、 両凹レンズと両凸レンズとの接合レンズ !_ 2 2と、 物体側に凹面を \¥02020/174865 22 卩(:170?2019/050965 2 1, a cemented lens of a biconcave lens and a biconvex lens !_ 2 2, and a concave surface on the object side. \¥02020/174865 22 卩 (: 170?2019/050965
向けた負レンズ 1- 2 3とで構成される。 It is composed of a negative lens 1 to 2 3 facing toward.
[0108] 第 3レンズ群 0 3は、 1枚の第 1 自由曲面レンズ !_ 3で構成され、 第 4レ ンズ群 0 4は 1枚の第 2自由曲面レンズ !_ 4で構成され、 第 1 自由曲面レン ズ !_ 3と第 2自由曲面レンズ !_ 4は 軸に対して反転した状態で配置される [0108] The third lens group 0 3 is composed of one first free-form surface lens !_ 3, and the fourth lens group 0 4 is composed of one second free-form surface lens !_ 4. 1 Free-form surface lens !_ 3 and 2nd free-form surface lens !_ 4 are arranged with their axes inverted.
[0109] 第 5レンズ群 0 5は、 両凸形状の正レンズ !_ 5 1 と、 物体側に凸面を向け た正レンズと像側に凹面を向けた負レンズとの接合レンズ !_ 5 2とで構成さ れる。 [0109] The fifth lens group 0 5 is a cemented lens which is a biconvex positive lens !_ 5 1 and a positive lens with a convex surface facing the object side and a negative lens with a concave surface facing the image side !_ 5 2 It consists of and.
[01 10] 第 6レンズ群◦ 6は両凸形状の正レンズ!- 6で構成される。 [01 10] 6th lens group ◦ 6 is a biconvex positive lens! -Composed of 6.
[01 1 1 ] 第 7レンズ群◦ 7は像側に凹面を向けた負レンズ !_ 7で構成される。 [01 1 1] The seventh lens group ◦ 7 is composed of a negative lens !_ 7 having a concave surface facing the image side.
[01 12] 第 8レンズ群◦ 8は物体側に凸面を向けた正レンズ !_ 8で構成される。 [01 12] The eighth lens group ◦ 8 is composed of a positive lens !_ 8 with a convex surface facing the object side.
[01 13] 尚、 第 2実施例においては、 第 1 自由曲面レンズ !_ 3と第 2自由曲面レン ズ!_ 4の丫軸方向における移動量が僅かに相違する。 これにより、 可変焦点 距離レンズ系 2の丫軸方向における小型化を図ることが可能になる。 In the second example, the movement amounts of the first free-form surface lens !_ 3 and the second free-form surface lens !_ 4 in the vertical axis direction are slightly different. This makes it possible to reduce the size of the variable focal length lens system 2 in the vertical axis direction.
[01 14] 以下の表 6〜表 9に本技術における第 2実施例の諸元の値を示す。 表 6に は各レンズの曲率半径等のレンズデータを示し、 表 7には焦点距離を変化さ せる際の可変間隔と移動量 (ズーム変位量) を示し、 表 8には自由曲面レン ズの形状を表す X V自由曲面係数 (X V多項式係数) 、 表 9には非球面係数 を示す。 [0114] Tables 6 to 9 below show values of specifications of the second embodiment of the present technology. Table 6 shows lens data such as the radius of curvature of each lens, Table 7 shows the variable distance and the amount of movement (zoom displacement) when changing the focal length, and Table 8 shows the free-form surface lens. The XV free-form surface coefficient (XV polynomial coefficient) that represents the shape and Table 9 show the aspherical surface coefficient.
[01 15] 尚、 以下の各表や説明において示した記号の意味等については、 下記に示 す通りである。 [0115] The meanings of the symbols shown in the following tables and explanations are as shown below.
[01 16] 表 6において、 「曲率半径」 は曲率の逆数を示し、 「曲率半径」 において 「0」 は平面を示し、 「口 11」 は第 番目の面と第 + 1番目の面の間の可 変間隔である軸上面間隔 (レンズの中心の厚み又は空気間隔) を示し、 「屈 折率」 と 「アッベ数」 は 線 (ス = 5 8 7 . 6 n m) における屈折率とアッ ベ数を示す。 表 7において、 「X」 、 「7」 はそれぞれ X軸方向と丫軸方向 における各値を示し、 「丫シフト量」 は第 1 自由曲面レンズ !_ 3と第 2自由 曲面レンズ 1- 4の丫軸方向における移動量を示す。 \¥02020/174865 23 卩(:17 2019/050965[01 16] In Table 6, "radius of curvature" indicates the reciprocal of curvature, "0" in "radius of curvature" indicates a plane, and "mouth 11" is between the 1st and +1st surfaces. The axial distance (the thickness of the center of the lens or the air distance), which is the variable distance between the two, is the refractive index and the Abbe number at the line (s = 5 87.6 nm). Indicates a number. In Table 7, “X” and “ 7 ” indicate the respective values in the X-axis direction and the vertical axis direction, and the “shift amount” is for the first free-form surface lens !_ 3 and the second free-form surface lens 1-4. Indicates the amount of movement in the vertical axis direction. \¥02020/174865 23 卩(: 17 2019/050965
[0117] [表 6][0117] [Table 6]

[0118] [表 7] [0118] [Table 7]
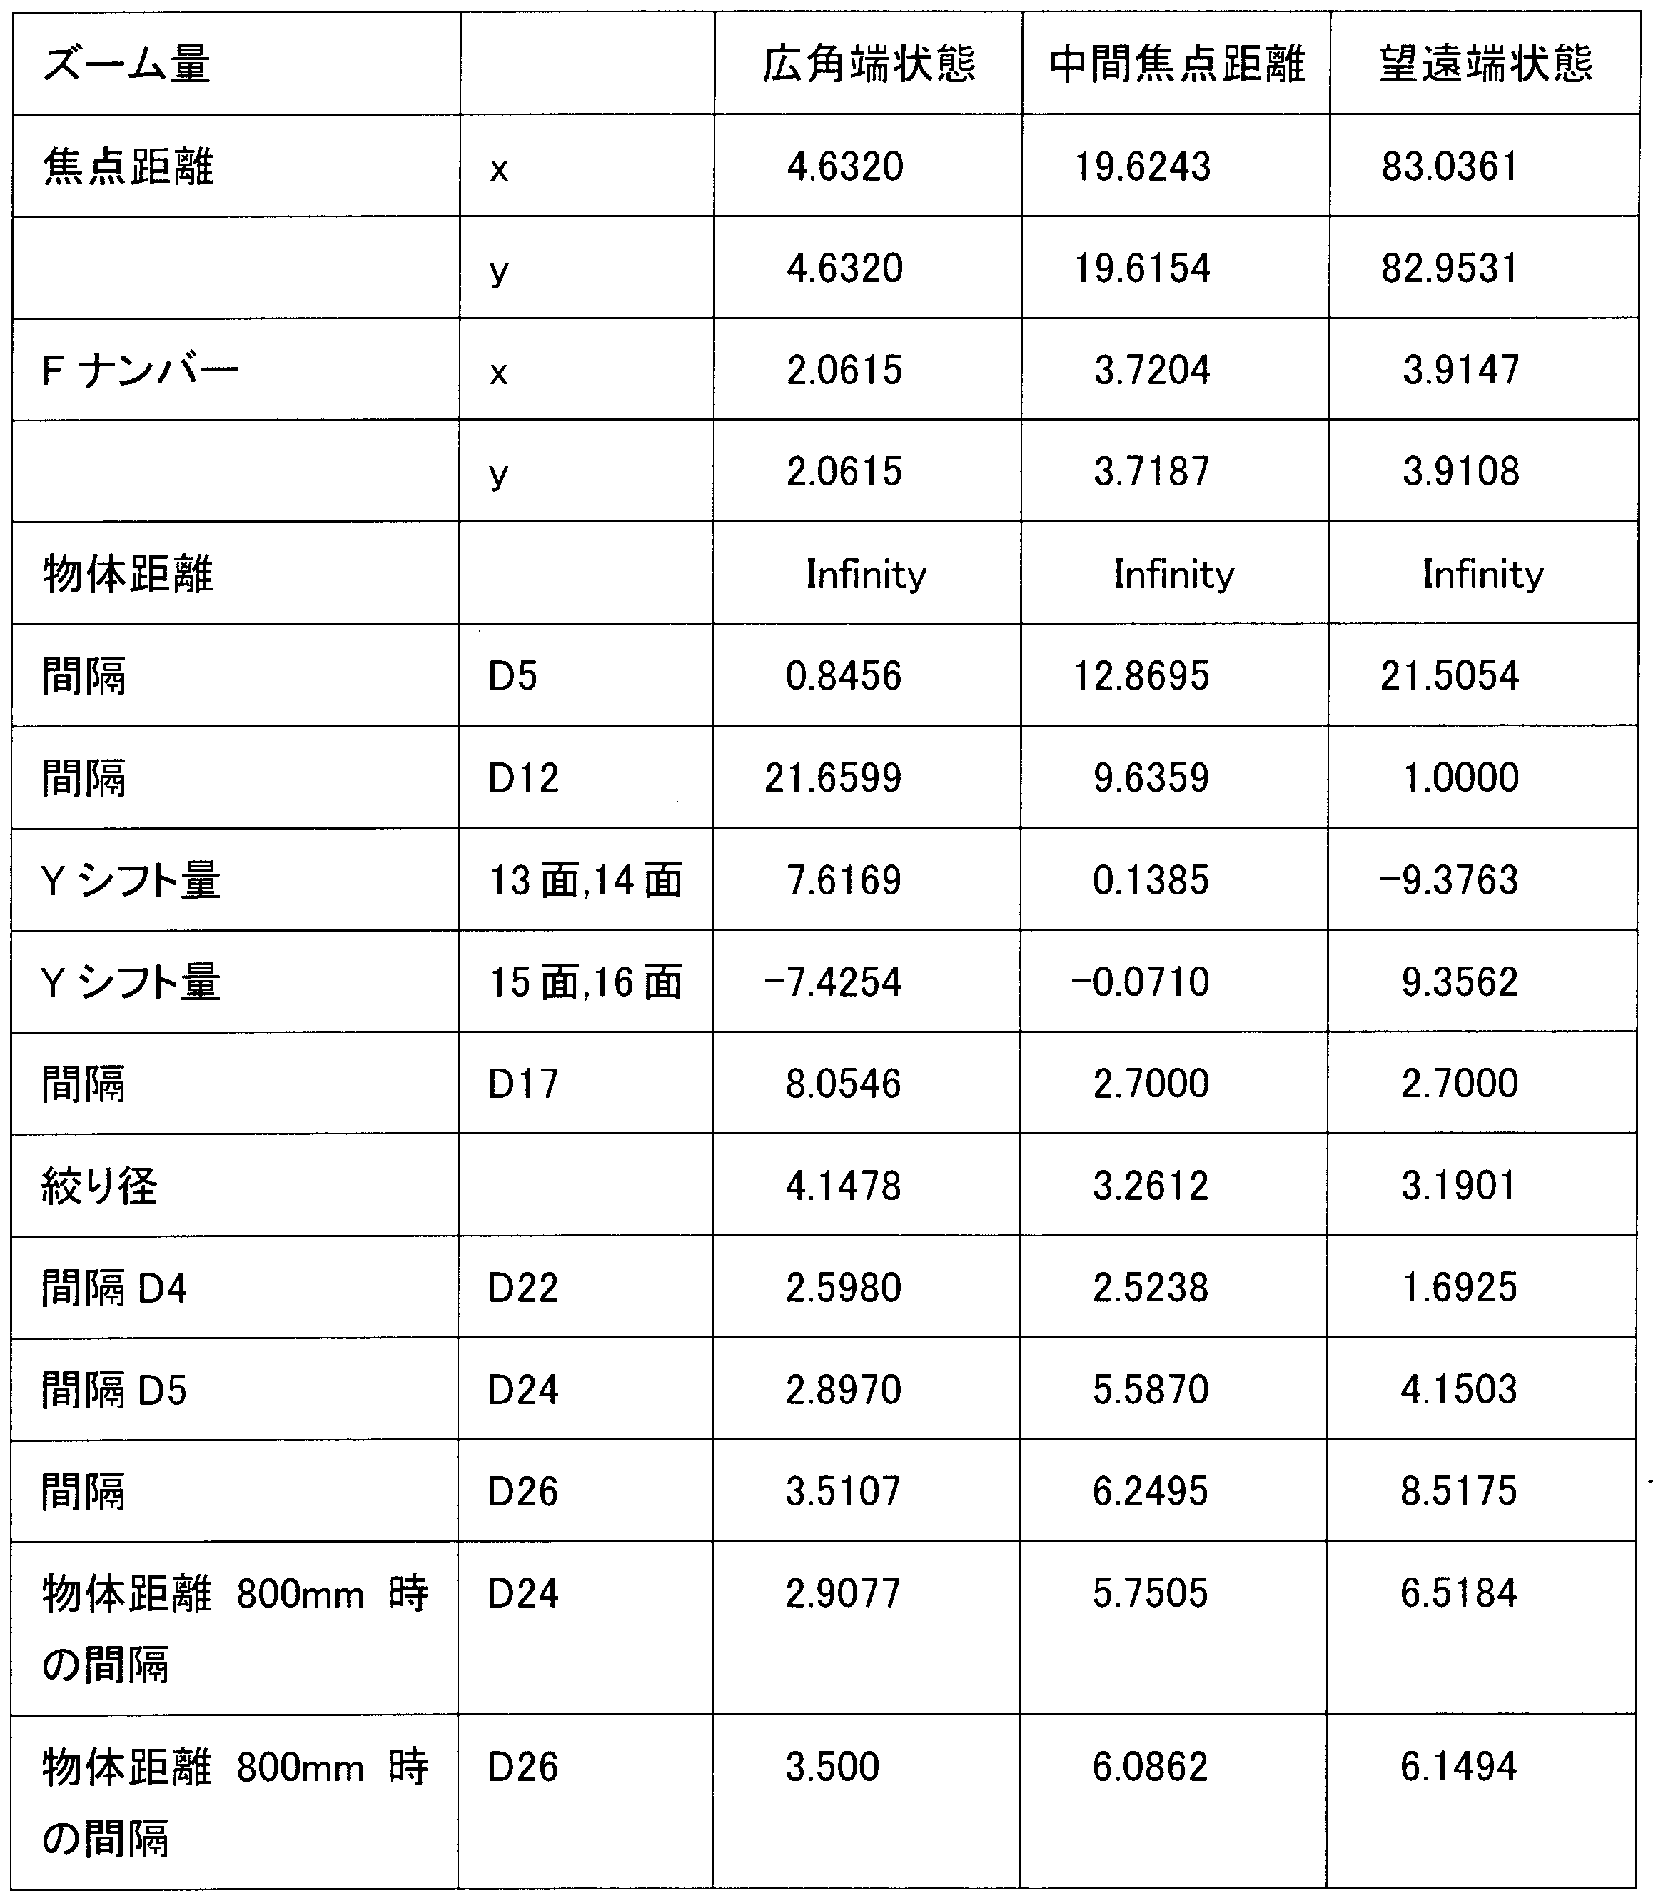
[0119] [0119]
\¥02020/174865 25 卩(:17 2019/050965\¥02020/174865 25 卩 (: 17 2019/050965
[表 8][Table 8]

[0120] [0120]
\¥02020/174865 26 卩(:17 2019/050965 \¥02020/174865 26 卩(: 17 2019/050965
[表 9] [Table 9]
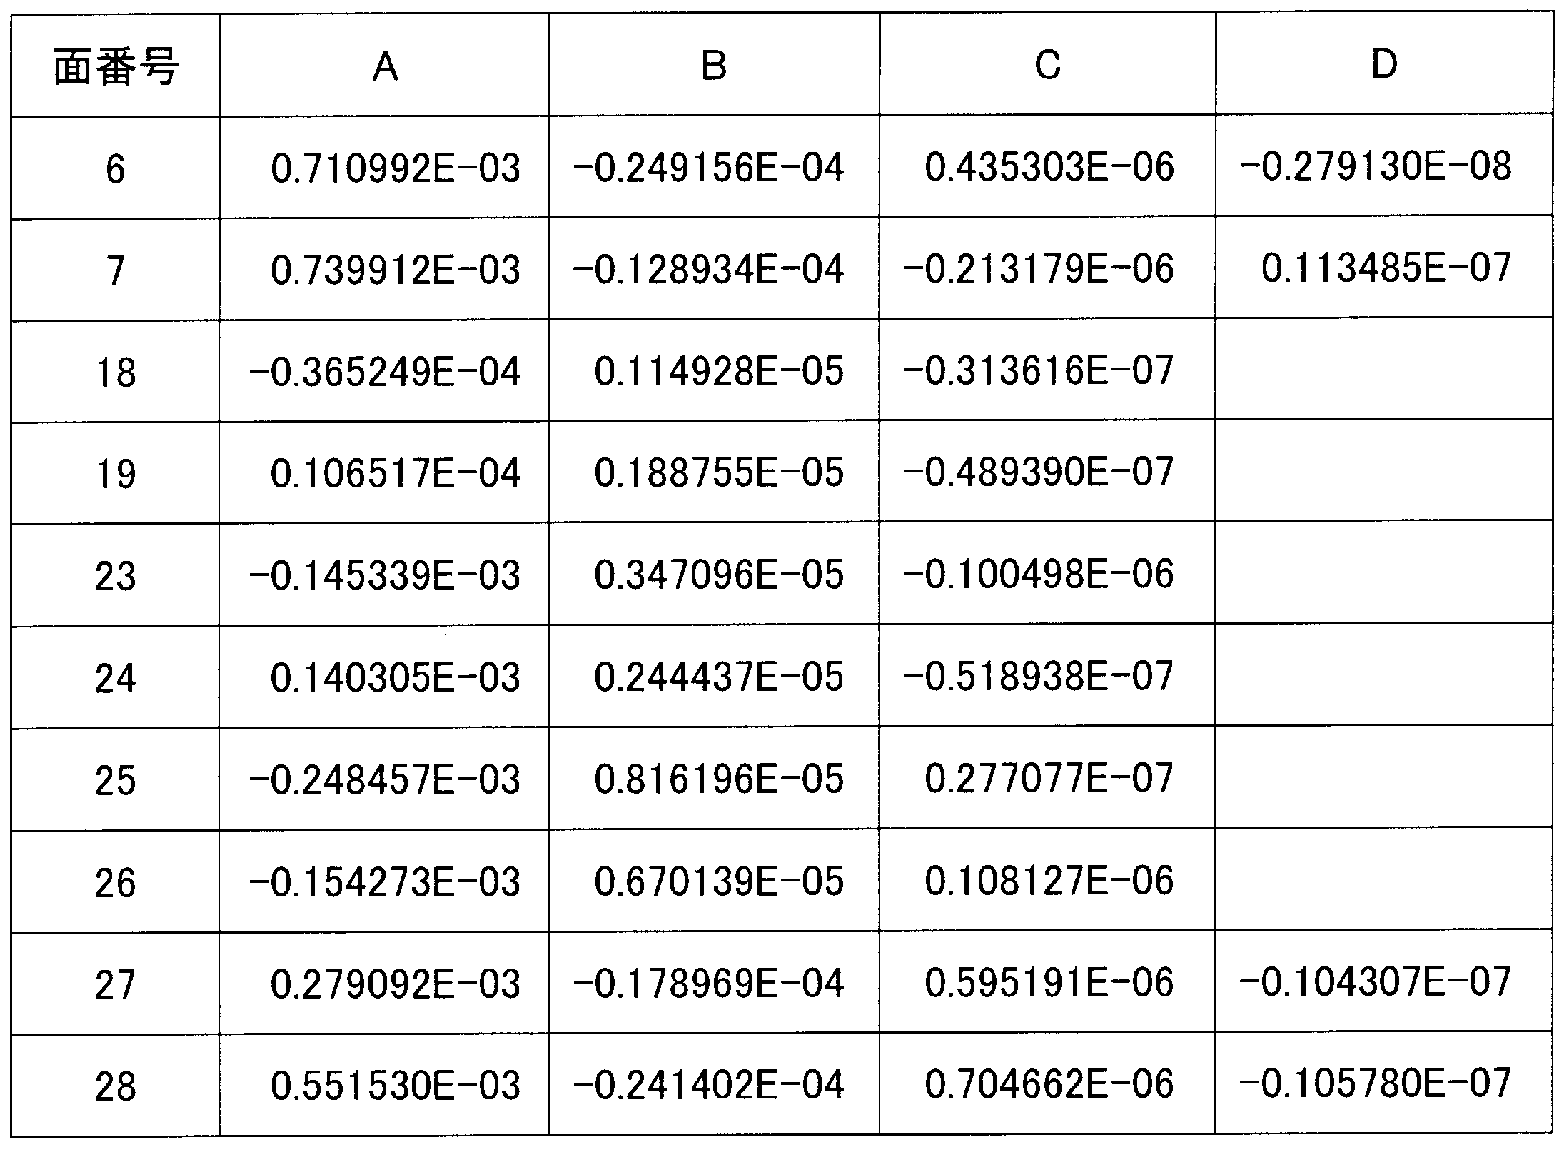
[0121] 表 1 0に第 2実施例における条件式の対応値を示す。 [0121] Table 10 shows the corresponding values of the conditional expressions in the second embodiment.
[0122] [0122]
\¥02020/174865 27 卩(:170?2019/050965 \¥02020/174865 27 卩 (: 170?2019/050965
[表 10] [Table 10]

[0123] 図 6には第 2実施例の広角端状態と望遠端状態におけるスポッ トダイヤグ ラムを示し、 図 7には第 2実施例の歪曲収差図を示す。 [0123] Fig. 6 shows the spot diagram of the second example in the wide-angle end state and the telephoto end state, and Fig. 7 shows the distortion diagram of the second example.
[0124] 各収差図から、 本実施例は諸収差が良好に補正され、 優れた結像性能を有 していることが明らかである。 [0124] From each aberration diagram, it is apparent that various aberrations are satisfactorily corrected and that this example has excellent imaging performance.
[0125] <第 3実施例> [0125] <Third embodiment>
図 8は、 本技術の第 3実施例に係る可変焦点距離レンズ系 3のレンズ断面 図を示す。 FIG. 8 shows a lens cross-sectional view of a variable focal length lens system 3 according to the third example of the present technology.
[0126] 第 1 レンズ群◦ 1は、 像側に凹面を向けたメニスカス形状の負レンズと物 体側に凸面を向けた正レンズとの接合レンズ !_ 1 1 と、 物体側に凸面を向け たメニスカス形状の正レンズ !_ 1 2とで構成される。 [0126] The first lens group ◦ 1 has a cemented lens !_ 1 1 consisting of a negative meniscus lens with a concave surface facing the image side and a positive lens with a convex surface facing the object side, and a convex surface facing the object side. It consists of a meniscus-shaped positive lens !_ 1 2.
[0127] 第 2レンズ群 0 2は、 像側に凹面を向けた負レンズ !_ 2 1 と、 両凹レンズ と両凸レンズとの接合レンズ!- 2 2と、 物体側に凹面を向けた負レンズ !_ 2 \¥02020/174865 28 卩(:170?2019/050965 [0127] The second lens group 0 2 is a negative lens !_ 21 with a concave surface facing the image side, and a cemented lens of a biconcave lens and a biconvex lens! -2 2 and a negative lens with concave surface facing the object side !_ 2 \¥02020/174865 28 卩 (: 170?2019/050965
3とで構成される。 Composed of 3 and.
[0128] 第 3レンズ群 0 3は、 1枚の第 1 自由曲面レンズ !_ 3で構成され、 第 4レ ンズ群 0 4は 1枚の第 2自由曲面レンズ !_ 4で構成され、 第 1 自由曲面レン ズ !_ 3と第 2自由曲面レンズ !_ 4は 軸に対して反転した状態で配置される [0128] The third lens group 0 3 is composed of one first free-form surface lens !_ 3, and the fourth lens group 0 4 is composed of one second free-form surface lens !_ 4. 1 Free-form surface lens !_ 3 and 2nd free-form surface lens !_ 4 are arranged with their axes inverted.
[0129] 第 5レンズ群 0 5は、 両凸形状の正レンズ !_ 5 1 と、 物体側に凸面を向け た正レンズと像側に凹面を向けた負レンズとの接合レンズ !_ 5 2とで構成さ れる。 [0129] The fifth lens group 0 5 is a cemented lens which is a biconvex positive lens !_ 5 1 and a positive lens with a convex surface facing the object side and a negative lens with a concave surface facing the image side !_ 5 2 It consists of and.
[0130] 第 6レンズ群◦ 6は両凸形状の正レンズ!- 6で構成される。 [0130] 6th lens group ◦ 6 is a positive biconvex lens! -Composed of 6.
[0131 ] 第 7レンズ群◦ 7は像側に凹面を向けた負レンズ !_ 7で構成される。 [0131] The seventh lens group ◦ 7 is composed of a negative lens !_ 7 having a concave surface facing the image side.
[0132] 第 8レンズ群◦ 8は像側に凸面を向けた正レンズ !_ 8で構成される。 [0132] The eighth lens unit ◦ 8 is composed of a positive lens !_ 8 having a convex surface facing the image side.
[0133] 以下の表 1 1〜表 1 4に本技術における第 3実施例の諸元の値を示す。 表 [0133] Tables 11 to 14 below show values of specifications of the third embodiment of the present technology. table
1 1 には各レンズの曲率半径等のレンズデータを示し、 表 1 2には焦点距離 を変化させる際の可変間隔と移動量 (ズーム変位量) を示し、 表 1 3には自 由曲面レンズの形状を表す XV自由曲面係数 (XV多項式係数) 、 表 1 4に は非球面係数を示す。 1 1 shows lens data such as the radius of curvature of each lens, Table 12 shows the variable interval and movement amount (zoom displacement amount) when changing the focal length, and Table 13 shows the free curved lens. XV free-form surface coefficient (XV polynomial coefficient) that represents the shape of, and Table 14 shows aspherical surface coefficients.
[0134] 尚、 以下の各表や説明において示した記号の意味等については、 下記に示 す通りである。 [0134] The meanings of the symbols shown in the following tables and explanations are as shown below.
[0135] 表 1 1 において、 「曲率半径」 は曲率の逆数を示し、 「曲率半径」 におい て 「0」 は平面を示し、 「口 11」 は第 番目の面と第 + 1番目の面の間の 可変間隔である軸上面間隔 (レンズの中心の厚み又は空気間隔) を示し、 「 屈折率」 と 「アッベ数」 は 線 (ス = 5 8 7 . 6 n m) における屈折率とア ッべ数を示す。 表 1 2において、 「X」 、 「7」 はそれぞれ X軸方向と丫軸 方向における各値を示し、 「丫シフト量」 は第 1 自由曲面レンズ !_ 3と第 2 自由曲面レンズ 1- 4の丫軸方向における移動量を示す。 [0135] In Table 11, "radius of curvature" indicates the reciprocal of curvature, "0" in the "radius of curvature" indicates a plane, and "mouth 11" indicates the 1st surface and the +1st surface. Shows the axial spacing (the thickness of the center of the lens or the air spacing) that is a variable spacing between the two. The "refractive index" and "Abbe number" are the refractive index and the abbe Indicates a number. In Table 12, " X " and " 7 " indicate the respective values in the X-axis direction and the vertical axis direction, and the "shift amount" is the first free-form surface lens !_ 3 and the second free-form surface lens 1-4. The amount of movement in the direction of the vertical axis of is shown.
[0136] \¥02020/174865 29 卩(:17 2019/050965[0136] \\02020/174865 29 卩(: 17 2019/050965
[表 11][Table 11]

[0137] \¥0 2020/174865 30 卩(:17 2019/050965[0137] \¥0 2020/174865 30 卩 (: 17 2019/050965
[表 12][Table 12]

[0138] [0138]
\¥0 2020/174865 31 卩(:17 2019/050965 \\0 2020/174865 31 卩(: 17 2019/050965
[表 13] [Table 13]

[0139] [表 14] [0139] [Table 14]

[0140] 表 1 5に第 3実施例における条件式の対応値を示す。 [0140] Table 15 shows the corresponding values of the conditional expressions in the third embodiment.
[0141 ] \¥02020/174865 32 卩(:170?2019/050965 [0141] \¥02020/174865 32 units (: 170?2019/050965
[表 1 5] [Table 15]

[0142] 図 9には第 3実施例の広角端状態と望遠端状態におけるスポッ トダイヤグ ラムを示し、 図 1 〇には第 3実施例の歪曲収差図を示す。 [0142] Fig. 9 shows the spot diagram of the third example in the wide-angle end state and the telephoto end state, and Fig. 10 shows the distortion diagram of the third example.
[0143] 各収差図から、 本実施例は諸収差が良好に補正され、 優れた結像性能を有 していることが明らかである。 [0143] From each aberration diagram, it is apparent that various aberrations are satisfactorily corrected and that this example has excellent imaging performance.
[0144] [撮像装置の構成] [0144] [Structure of imaging device]
本技術の撮像装置は、 可変焦点距離レンズ系が、 物体側より像側へ順に、 少なくとも一つのレンズ群で構成される第 1 レンズユニッ トと、 第 1 自由曲 面レンズと第 2自由曲面レンズで構成される第 2レンズユニッ トと、 少なく とも一つのレンズ群で構成される第 3レンズユニッ トとにより構成されてい る。 The imaging device of the present technology has a variable focal length lens system in which the first lens unit is composed of at least one lens group in order from the object side to the image side, the first free-form surface lens and the second free-form surface lens. It is composed of a second lens unit composed of and a third lens unit composed of at least one lens group.
[0145] また、 本技術の撮像装置は、 可変焦点距離レンズ系が、 第 1 レンズュニッ 卜と第 3レンズュニッ トは光軸に対して回転対称な形状のレンズで構成され \¥02020/174865 33 卩(:170?2019/050965 [0145] Further, in the imaging device of the present technology, the variable focal length lens system is configured, and the first lens unit and the third lens unit are composed of lenses that are rotationally symmetric with respect to the optical axis. \¥02020/174865 33 卩 (: 170?2019/050965
ると共に同じ光軸上に配置され、 第 1 自由曲面レンズと第 2自由曲面レンズ は同一形状にされ光軸に対して 1 8 0度回転して配置されている。 In addition, they are arranged on the same optical axis, and the first free-form surface lens and the second free-form surface lens have the same shape and are arranged by rotating 180 degrees with respect to the optical axis.
[0146] さらに、 本技術の撮像装置は、 可変焦点距離レンズ系が、 第 1 レンズユニ ッ トと第 3レンズユニッ トの光軸を 軸とし、 像面上で 軸に垂直な軸を丫 軸とし、 像面上で丫軸と 軸に垂直な軸を乂軸とすると、 第 1 自由曲面レン ズと第 2自由曲面レンズは丫軸方向へ移動可能である。 [0146] Furthermore, in the imaging device of the present technology, the variable focal length lens system has the optical axes of the first lens unit and the third lens unit as axes, and the axis perpendicular to the axes on the image plane as the lower axis. The first free-form surface lens and the second free-form surface lens can move in the direction of the vertical axis, where the vertical axis on the image plane and the axis perpendicular to the axis are the vertical axes.
[0147] 加えて、 本技術の撮像装置は、 可変焦点距離レンズ系が、 第 1 自由曲面レ ンズと第 2自由曲面レンズが互いに逆方向へ移動することにより第 2レンズ ユニッ トの屈折力が可変であり、 焦点距離が最も短い広角端状態から焦点距 離が最も長い望遠端状態までレンズの位置状態が変化する際に、 第 1 レンズ ユニッ トと第 3レンズユニッ トを構成するレンズ群の一部が移動するのと合 わせて、 第 1 自由曲面レンズと第 2自由曲面レンズが丫軸方向へ移動する。 [0147] In addition, in the imaging device of the present technology, the variable focal length lens system moves the first free-form surface lens and the second free-form surface lens in opposite directions, so that the refractive power of the second lens unit is increased. It is variable, and when the lens position changes from the wide-angle end state where the focal length is the shortest to the telephoto end state where the focal length is the longest, the lens groups that make up the first lens unit and the third lens unit Along with the partial movement, the first free-form surface lens and the second free-form surface lens move in the axial direction.
[0148] 本技術の撮像装置は、 可変焦点距離レンズ系が、 第 1 自由曲面レンズと第 [0148] In the imaging device of the present technology, the variable focal length lens system includes the first free-form surface lens and the first free-form surface lens.
2自由曲面レンズが同じ形状で 軸に対して 1 8 0度回転されて配置される 。 そして、 第 1 自由曲面レンズと第 2自由曲面レンズが互いに逆方向へ移動 することで、 第 2レンズユニッ トの合成屈折力が変化する。 これと一般的な ズームレンズとを組合せることで、 像面位置を一定に保ちながら光学全長を 短縮化する。 2 Free-form surface lenses are arranged in the same shape, rotated 180 degrees about the axis. Then, the combined refractive power of the second lens unit changes as the first free-form surface lens and the second free-form surface lens move in opposite directions. By combining this with a general zoom lens, the overall optical length can be shortened while keeping the image plane position constant.
[0149] 従来のズームレンズは各レンズ群の移動方向が光軸方向しかなかったのに 対して、 本技術の撮像装置は、 可変焦点距離レンズ系の二つの自由曲面レン ズを光軸方向以外に移動させることで焦点距離を変化させる自由度を増やし ている。 [0149] Whereas in the conventional zoom lens, the moving direction of each lens group is only the optical axis direction, the image pickup device of the present technology uses the two free-form surface lenses of the variable focal length lens system other than the optical axis direction. The degree of freedom to change the focal length is increased by moving to.
[0150] 特に、 第 1 自由曲面レンズと第 2自由曲面レンズを同一形状とすることで 、 自由曲面の形状が滑らかになり、 停止位置のズレや自由曲面の偏心 (物体 側と像側のレンズ面同士の倒れや移動) による性能低下を防ぐことを可能と した。 [0150] In particular, by making the first free-form surface lens and the second free-form surface lens the same shape, the shape of the free-form surface becomes smooth, and the shift of the stop position and the eccentricity of the free-form surface (the lens on the object side and the image side) It has become possible to prevent performance deterioration due to the surfaces collapsing or moving.
[0151 ] また、 焦点距離を変化させる際に、 第 1 自由曲面レンズと第 2自由曲面レ ンズを逆方向へ同じ量だけ移動させることで、 非対称な形状に起因する収差 \¥02020/174865 34 卩(:170?2019/050965 [0151] Also, when the focal length is changed, by moving the first free-form surface lens and the second free-form surface lens by the same amount in opposite directions, the aberration caused by the asymmetrical shape can be obtained. \¥02020/174865 34 卩 (: 170?2019/050965
の発生を第 1 自由曲面レンズと第 2自由曲面レンズの二つのレンズで互いに 打ち消して、 良好な光学性能を実現した。 The occurrence of is canceled out by the two lenses, the first free-form surface lens and the second free-form surface lens, and good optical performance is realized.
[0152] 上記のように、 本技術の撮像装置は、 各種の効果を奏し、 小型で高倍率な 撮像装置を提供することができる。 [0152] As described above, the imaging device of the present technology can provide various effects, and can provide a small-sized and high-magnification imaging device.
[0153] [撮像装置の一実施形態] [One Embodiment of Imaging Device]
図 1 1 に、 本技術の撮像装置の一実施形態によるデジタルスチルカメラの ブロック図を示す。 FIG. 11 shows a block diagram of a digital still camera according to an embodiment of an imaging device of the present technology.
[0154] 撮像装置 (デジタルスチルカメラ) 1 0 0は、 取り込まれた光を電気信号 に変換する光電変換機能を有する撮像素子 1 〇と、 撮影された画像信号のァ ナログーデジタル変換等の信号処理を行うカメラ信号処理部 2 0と、 画像信 号の記録再生処理を行う画像処理部 3 0とを有している。 また、 撮像装置 1 0 0は、 撮影された画像等を表示する表示部 4 0と、 メモリー 9 0への画像 信号の書込及び読出を行う


[0155] カメラ信号処理部 2 0は、 撮像素子 1 0からの出力信号に対するデジタル 信号への変換、 ノイズ除去、 画質補正、 輝度 ·色差信号への変換等の各種の 信号処理を行う。 [0155] The camera signal processing unit 20 performs various kinds of signal processing such as conversion of an output signal from the image sensor 10 into a digital signal, noise removal, image quality correction, and conversion into a luminance/color difference signal.
[0156] 画像処理部 3 0は、 所定の画像データフォーマッ トに基づく画像信号の圧 縮符号化 ·伸張復号化処理や解像度等のデータ仕様の変換処理等を行う。 [0156] The image processing unit 30 performs compression coding/expansion decoding processing of an image signal based on a predetermined image data format, conversion processing of data specifications such as resolution, and the like.
[0157] 表示部 4 0はユーザーの入力部 7 0に対する操作状態や撮影した画像等の 各種のデータを表示する機能を有している。 [0157] The display section 40 has a function of displaying various data such as an operation state of the user's input section 70 and a captured image.
[0158] 0は、 画像処理部 3 0によって符号化された画像データのメモリ [0158] 0 is a memory for image data encoded by the image processing unit 30.
_ 9 0への書込及びメモリー 9 0に記録された画像データの読出を行う。 _ 90 is written and image data recorded in the memory 90 is read.
[0159] 0 II 6 0は、 撮像装置 1 0 0に設けられた各回路ブロックを制御する制 御処理部として機能し、 入力部 7 0からの指示入力信号等に基づいて各回路 ブロックを制御する。 \¥0 2020/174865 35 卩(:170?2019/050965 [0159] The 0 II 60 functions as a control processing unit that controls each circuit block provided in the imaging device 100, and controls each circuit block based on an instruction input signal from the input unit 70. To do. \\0 2020/174865 35 卩 (: 170?2019/050965
[0160] 入力部 7 0はユーザーによる操作に応じた指示入力信号を〇 II 6 0に対 して出力する。 [0160] The input section 70 outputs an instruction input signal corresponding to the user's operation to 〇II60.
[0161 ] レンズ駆動制御部 8 0は、 0 9 1\ 6 0からの制御信号に基づいてレンズ群 を駆動する図示しないモータ等を制御する。 [0161] The lens drive control unit 80 controls a motor or the like (not shown) that drives the lens group based on the control signal from 091\60.
[0162] メモリー 9 0は、 例えば、

[0163] 以下に、 撮像装置 1 0 0における動作を説明する。 [0163] The operation of the image pickup apparatus 100 will be described below.
[0164] 撮影の待機状態では、 0 II 6 0による制御の下で、 撮影された画像信号 がカメラ信号処理部 2 0を介して表示部 4 0に出力され、 カメラスルー画像 として表示される。 [0164] In the standby state for shooting, under the control of 0 II 60, the shot image signal is output to the display unit 40 via the camera signal processing unit 20 and displayed as a camera through image.
[0165] 入力部 7 0からの指示入力信号により撮影が行われると、 撮影された画像 信号がカメラ信号処理部 2 0から画像処理部 3 0に出力されて圧縮符号化処 理され、 所定のデータフォーマッ トのデジタルデータに変換される。 変換さ れたデータは

[0166] フォーカシングは〇 II 6 0からの制御信号に基づいてレンズ駆動制御部 [0166] Focusing is based on the control signal from II 60.
8 0がフォーカスレンズ群を移動させることにより行われる。 80 is performed by moving the focus lens group.
[0167] メモリー 9 0に記録された画像データを再生する場合には、 入力部 7 0に 対する操作に応じて

[0168] 尚、 本技術において、 「撮像」 とは、 撮像素子 1 0による取り込まれた光 を電気信号に変換する光電変換処理から、 カメラ信号処理部 2 0による撮像 素子 1 0からの出力信号に対するデジタル信号への変換、 ノイズ除去、 画質 補正、 輝度 ·色差信号への変換等の処理、 画像処理部 3 0による所定の画像 データフォーマッ トに基づく画像信号の圧縮符号化 ·伸張復号化処理や解像 度等のデータ仕様の変換処理、

う。 Uh.
[0169] 即ち、 「撮像」 とは、 撮像素子 1 0による取り込まれた光を電気信号に変 換する光電変換処理のみを指してもよく、 撮像素子 1 〇による取り込まれた 光を電気信号に変換する光電変換処理からカメラ信号処理部 2 0による撮像 素子 1 0からの出力信号に対するデジタル信号への変換、 ノイズ除去、 画質 補正、 輝度 ·色差信号への変換等の処理までを指してもよく、 撮像素子 1 〇 による取り込まれた光を電気信号に変換する光電変換処理からカメラ信号処 理部 2 0による撮像素子 1 0からの出力信号に対するデジタル信号への変換 、 ノイズ除去、 画質補正、 輝度 ·色差信号への変換等の処理を経て、 画像処 理部 3 0による所定の画像データフォーマッ トに基づく画像信号の圧縮符号 化 ·伸張復号化処理や解像度等のデータ仕様の変換処理までを指してもよく 、 撮像素子 1 〇による取り込まれた光を電気信号に変換する光電変換処理か らカメラ信号処理部 2 0による撮像素子 1 0からの出力信号に対するデジタ ル信号への変換、 ノイズ除去、 画質補正、 輝度 ·色差信号への変換等の処理 、 及び画像処理部 3 0による所定の画像データフォーマッ トに基づく画像信 号の圧縮符号化 ·伸張復号化処理や解像度等のデータ仕様の変換処理を経て 指してもよく、

[0170] また、 本技術において、 撮影装置 1 0 0は、 上記の処理を行う撮像素子 1 〇、 カメラ信号処理部 2 0、 画像処理部 3 0、

[0171 ] [その他] [0171] [Others]
本技術の可変焦点距離レンズ系及び本技術の撮像装置においては、 第 1 レ ンズ群〇 1乃至第 8レンズ群〇 8に加えて屈折力を有さないレンズ等の他の 光学要素が配置されていてもよい。 この場合において、 本技術の可変焦点距 離レンズ系のレンズ構成は第 1 レンズ群〇 1乃至第 8レンズ群〇 8の実質的 に 8群のレンズ構成にされる。 \¥02020/174865 37 卩(:17 2019/050965 In the variable focal length lens system of the present technology and the image pickup apparatus of the present technology, in addition to the first lens group 0 1 to the eighth lens group 08, other optical elements such as lenses having no refractive power are arranged. May be. In this case, the lens configuration of the variable focal length lens system of the present technology is substantially the lens configuration of the first lens group 0 1 to the eighth lens group 08. \¥02020/174865 37 卩(: 17 2019/050965
[0172] 尚、 上記した撮像装置は、 デジタルスチルカメラ、 デジタルビデオカメラ 、 カメラが組み込まれた携帯電話、 カメラが組み込まれたタブレッ ト等の携 帯端末等のデジタル入出力機器のカメラ部等として広く適用することができ る。 [0172] The above-described imaging device is used as a camera unit of a digital input/output device such as a digital still camera, a digital video camera, a mobile phone with a built-in camera, or a portable terminal such as a tablet with a built-in camera. It can be widely applied.
[0173] [応用例 1 ] [0173] [Application example 1]
本開示に係る技術は、 様々な製品へ応用することができる。 例えば、 本開 示に係る技術は、 手術室システムに適用されてもよい。 The technology according to the present disclosure can be applied to various products. For example, the technology according to the present disclosure may be applied to an operating room system.
[0174] 図 1 2は、 本開示に係る技術が適用され得る手術室システム 5 1 0 0の全 体構成を概略的に示す図である。 図 1 2を参照すると、 手術室システム 5 1 0 0は、 手術室内に設置される装置群が視聴覚コントローラ (八\/

「) 5 1 0 7及び手術室制御装置 5 1 0 9を介して互いに連携可能に接続され ることにより構成される。 “) 510 and the operating room control device 510” are connected so that they can cooperate with each other.
[0175] 手術室には、 様々な装置が設置され得る。 図 1 2では、 一例として、 内視 鏡下手術のための各種の装置群 5 1 0 1 と、 手術室の天井に設けられ術者の 手元を撮像するシーリングカメラ 5 1 8 7と、 手術室の天井に設けられ手術 室全体の様子を撮像する術場カメラ 5 1 8 9と、 複数の表示装置 5 1 0 3八 〜 5 1 0 3 0と、 レコーダ 5 1 0 5と、 患者べッ ド 5 1 8 3と、 照明 5 1 9 1 と、 を図示している。 [0175] Various devices may be installed in the operating room. As an example, Fig. 12 shows a group of various devices for endoscopic surgery 5 101, a ceiling camera 5 1 8 7 installed on the ceiling of the operating room to image the operator's hand, and an operating room. An operating room camera 518 9 installed on the ceiling of the operating room to capture an image of the entire operating room, multiple display devices 5 1 0 3 8 to 5 1 0 3 0, a recorder 5 1 0 5 and a patient bed. 5 1 8 3 and lights 5 1 9 1 are shown.
[0176] ここで、 これらの装置のうち、 装置群 5 1 0 1は、 後述する内視鏡手術シ ステム 5 1 1 3に属するものであり、 内視鏡や当該内視鏡によって撮像され た画像を表示する表示装置等からなる。 内視鏡手術システム 5 1 1 3に属す る各装置は医療用機器とも呼称される。 一方、 表示装置 5 1 0 3 〜5 1 0 3 0 , レコーダ 5 1 0 5、 患者ベッ ド 5 1 8 3及び照明 5 1 9 1は、 内視鏡 手術システム 5 1 1 3とは別個に、 例えば手術室に備え付けられている装置 である。 これらの内視鏡手術システム 5 1 1 3に属さない各装置は非医療用 機器とも呼称される。 視聴覚コントローラ 5 1 0 7及び/又は手術室制御装 置 5 1 0 9は、 これら医療機器及び非医療機器の動作を互いに連携して制御 する。 \¥02020/174865 38 卩(:170?2019/050965 [0176] Here, among these devices, the device group 5101 belongs to an endoscopic surgery system 5113 described later, and is imaged by the endoscope or the endoscope. It is composed of a display device for displaying an image. Each device belonging to the endoscopic surgery system 5 1 1 3 is also called a medical device. On the other hand, the display devices 5103 to 5103, the recorder 5105, the patient bed 5183 and the illumination 5191 are separated from the endoscopic surgery system 5113. For example, a device installed in an operating room. Each device that does not belong to these endoscopic surgery systems 5 1 1 3 is also called a non-medical device. The audiovisual controller 510 and/or the operating room control device 510 control the operations of these medical devices and non-medical devices in cooperation with each other. \¥02020/174865 38 卩 (: 170?2019/050965
[0177] 視聴覚コントローラ 5 1 0 7は、 医療機器及び非医療機器における画像表 示に関する処理を、 統括的に制御する。 具体的には、 手術室システム 5 1 0 0が備える装置のうち、 装置群 5 1 0 1、 シーリングカメラ 5 1 8 7及び術 場カメラ 5 1 8 9は、 手術中に表示すべき情報 (以下、 表示情報ともいう) を発信する機能を有する装置 (以下、 発信元の装置とも呼称する) であり得 る。 また、 表示装置 5 1 0 3八~ 5 1 0 3 0は、 表示情報が出力される装置 (以下、 出力先の装置とも呼称する) であり得る。 また、 レコーダ 5 1 0 5 は、 発信元の装置及び出力先の装置の双方に該当する装置であり得る。 視聴 覚コントローラ 5 1 0 7は、 発信元の装置及び出力先の装置の動作を制御し 、 発信元の装置から表示情報を取得するとともに、 当該表示情報を出力先の 装置に送信し、 表示又は記録させる機能を有する。 なお、 表示情報とは、 手 術中に撮像された各種の画像や、 手術に関する各種の情報 (例えば、 患者の 身体情報や、 過去の検査結果、 術式についての情報等) 等である。 [0177] The audiovisual controller 5107 centrally controls the processing related to image display in medical devices and non-medical devices. Specifically, among the devices included in the operating room system 510, the device group 5101, the ceiling camera 5187 and the operating room camera 518 have information to be displayed during surgery (hereinafter , Which is also referred to as display information) (hereinafter, also referred to as a sender's device). In addition, the display devices 5103 to 5130 may be devices to which display information is output (hereinafter, also referred to as output destination devices). Further, the recorder 510 may be a device that corresponds to both the source device and the output destination device. The audiovisual controller 5107 controls the operations of the transmission source device and the output destination device, acquires display information from the transmission source device, and transmits the display information to the output destination device for display or It has a recording function. The display information includes various images taken during the operation, various information related to the surgery (for example, the patient's physical information, past examination results, information about the surgical procedure, etc.).
[0178] 具体的には、 視聴覚コントローラ 5 1 0 7には、 装置群 5 1 0 1から、 表 示情報として、 内視鏡によって撮像された患者の体腔内の術部の画像につい ての情報が送信され得る。 また、 シーリングカメラ 5 1 8 7から、 表示情報 として、 当該シーリングカメラ 5 1 8 7によって撮像された術者の手元の画 像についての情報が送信され得る。 また、 術場カメラ 5 1 8 9から、 表示情 報として、 当該術場カメラ 5 1 8 9によって撮像された手術室全体の様子を 示す画像についての情報が送信され得る。 なお、 手術室システム 5 1 0 0に 撮像機能を有する他の装置が存在する場合には、 視聴覚コントローラ 5 1 0 7は、 表示情報として、 当該他の装置からも当該他の装置によって撮像され た画像についての情報を取得してもよい。 [0178] Specifically, the audiovisual controller 5107 has information about the image of the surgical site in the body cavity of the patient, which is imaged by the endoscope, as display information from the device group 5101. Can be sent. Further, the ceiling camera 5187 can transmit, as the display information, information about the image of the operator's hand imaged by the ceiling camera 5187. Further, the operating room camera 5189 can transmit, as the display information, information about an image showing the state of the entire operating room imaged by the operating room camera 5189. If another device having an imaging function is present in the operating room system 510, the audiovisual controller 5107 is also displayed by the other device as the display information. Information about the image may be obtained.
[0179] あるいは、 例えば、 レコーダ 5 1 0 5には、 過去に撮像されたこれらの画 像についての情報が視聴覚コントローラ 5 1 0 7によって記録されている。 視聴覚コントローラ 5 1 0 7は、 表示情報として、 レコーダ 5 1 0 5から当 該過去に撮像された画像についての情報を取得することができる。 なお、 レ コーダ 5 1 0 5には、 手術に関する各種の情報も事前に記録されていてもよ い。 [0179] Alternatively, for example, in the recorder 5105, information about these images captured in the past is recorded by the audiovisual controller 5107. The audiovisual controller 5107 can acquire, as the display information, information about the image captured in the past from the recorder 5105. It should be noted that the recorder 510 may also record various information regarding surgery in advance. Yes.
[0180] 視聴覚コントローラ 5 1 0 7は、 出力先の装置である表示装置 5 1 0 3 A [0180] The audiovisual controller 5107 is a display device which is an output destination device.
〜 5 1 0 3 Dの少なくともいずれかに、 取得した表示情報 (すなわち、 手術 中に撮影された画像や、 手術に関する各種の情報) を表示させる。 図示する 例では、 表示装置 5 1 0 3 Aは手術室の天井から吊り下げられて設置される 表示装置であり、 表示装置 5 1 0 3 Bは手術室の壁面に設置される表示装置 であり、 表示装置 5 1 0 3 Cは手術室内の机上に設置される表示装置であり 、 表示装置 5 1 0 3 Dは表示機能を有するモバイル機器 (例えば、 タブレッ 卜 P C (Persona I Computer) ) である。 Display the acquired display information (that is, the image captured during the surgery and various information regarding the surgery) on at least one of the ~5103D. In the illustrated example, the display device 5 103 A is a display device that is installed by being suspended from the ceiling of the operating room, and the display device 5 103 B is a display device that is installed on the wall of the operating room. The display device 5103C is a display device installed on a desk in the operating room, and the display device 5103D is a mobile device having a display function (for example, a tablet PC (Persona I Computer)). ..
[0181 ] また、 図 1 2では図示を省略しているが、 手術室システム 5 1 0 0には、 手術室の外部の装置が含まれてもよい。 手術室の外部の装置は、 例えば、 病 院内外に構築されたネッ トワークに接続されるサーバや、 医療スタッフが用 いる P C、 病院の会議室に設置されるプロジェクタ等であり得る。 このよう な外部装置が病院外にある場合には、 視聴覚コントローラ 5 1 0 7は、 遠隔 医療のために、 テレビ会議システム等を介して、 他の病院の表示装置に表示 情報を表示させることもできる。 [0181] Although not shown in Fig. 12, the operating room system 510 may include a device outside the operating room. The device outside the operating room may be, for example, a server connected to a network built inside or outside the hospital, a PC used by medical staff, or a projector installed in a conference room of a hospital. When such an external device is located outside the hospital, the audiovisual controller 5107 may display the display information on the display device of another hospital via a video conference system or the like for remote medical treatment. it can.
[0182] 手術室制御装置 5 1 0 9は、 非医療機器における画像表示に関する処理以 外の処理を、 統括的に制御する。 例えば、 手術室制御装置 5 1 0 9は、 患者 ベッ ド 5 1 8 3、 シーリングカメラ 5 1 8 7、 術場カメラ 5 1 8 9及び照明 5 1 9 1の駆動を制御する。 [0182] The operating room control device 510 centrally controls processing other than processing related to image display in non-medical devices. For example, the operating room controller 5109 controls the drive of the patient bed 5183, the ceiling camera 518, the operating room camera 518 and the lighting 511.
[0183] 手術室システム 5 1 0 0には、 集中操作パネル 5 1 1 1が設けられており 、 ユーザは、 当該集中操作パネル 5 1 1 1 を介して、 視聴覚コントローラ 5 1 0 7に対して画像表示についての指示を与えたり、 手術室制御装置 5 1 0 9に対して非医療機器の動作についての指示を与えることができる。 集中操 作パネル 5 1 1 1は、 表示装置の表示面上にタッチパネルが設けられて構成 される。 [0183] The operating room system 510 is provided with a centralized operation panel 5 1 1 1, and the user uses the centralized operation panel 5 1 1 1 to connect to the audiovisual controller 5 1 0 7. It is possible to give an instruction for displaying an image and give an instruction for the operation of the non-medical device to the operating room control device 510. The centralized operation panel 5 1 1 1 1 is configured by providing a touch panel on the display surface of the display device.
[0184] 図 1 3は、 集中操作パネル 5 1 1 1 における操作画面の表示例を示す図で ある。 図 1 3では、 一例として、 手術室システム 5 1 0 0に、 出力先の装置 として、 2つの表示装置が設けられている場合に対応する操作画面を示して いる。 図 1 3を参照すると、 操作画面 5 1 9 3には、 発信元選択領域 5 1 9 5と、 プレビュー領域 5 1 9 7と、 コントロール領域 5 2 0 1 と、 が設けら れる。 [0184] Fig. 13 is a diagram showing a display example of an operation screen on the centralized operation panel 5 1 1 1. In Fig. 13, as an example, the operating room system 510 is connected to the output device. Shows the operation screen corresponding to the case where two display devices are provided. Referring to FIG. 13, the operation screen 5 1 9 3 is provided with a source selection area 5 1 9 5, a preview area 5 1 9 7 and a control area 5 2 0 1.
[0185] 発信元選択領域 5 1 9 5には、 手術室システム 5 1 0 0に備えられる発信 元装置と、 当該発信元装置が有する表示情報を表すサムネイル画面と、 が紐 付けられて表示される。 ユーザは、 表示装置に表示させたい表示情報を、 発 信元選択領域 5 1 9 5に表示されているいずれかの発信元装置から選択する ことができる。 [0185] In the sender selection area 5195, the sender device provided in the operating room system 510 and the thumbnail screen showing the display information of the sender device are displayed in association with each other. It The user can select the display information to be displayed on the display device from any of the transmission source devices displayed in the transmission source selection area 5 195.
[0186] プレビュー領域 5 1 9 7には、 出力先の装置である 2つの表示装置 (Mon i t or U Mon i tor2) に表示される画面のプレビューが表示される。 図示する例で は、 1つの表示装置において 4つの画像が P i n P表示されている。 当該 4 つの画像は、 発信元選択領域 5 1 9 5において選択された発信元装置から発 信された表示情報に対応するものである。 4つの画像のうち、 1つはメイン 画像として比較的大きく表示され、 残りの 3つはサブ画像として比較的小さ く表示される。 ユーザは、 4つの画像が表示された領域を適宜選択すること により、 メイン画像とサブ画像を入れ替えることができる。 また、 4つの画 像が表示される領域の下部には、 ステータス表示領域 5 1 9 9が設けられて おり、 当該領域に手術に関するステータス (例えば、 手術の経過時間や、 患 者の身体情報等) が適宜表示され得る。 [0186] In the preview area 5197, a preview of the screen displayed on the two display devices (Monit or U Monitor) that are the output destination devices is displayed. In the example shown, four images are displayed in P in P on one display device. The four images correspond to the display information transmitted from the transmission source device selected in the transmission source selection area 5195. Of the four images, one is displayed relatively large as the main image and the remaining three are displayed relatively small as sub-images. The user can switch the main image and the sub image by appropriately selecting the area in which the four images are displayed. A status display area 519 9 is provided below the area where the four images are displayed, and the status related to the operation (for example, the elapsed time of the operation, the physical information of the patient, etc.) is provided in the area. ) Can be displayed as appropriate.
[0187] コントロール領域 5 2 0 1 には、 発信元の装置に対して操作を行うための G U I (Graph i ca l User Interface) 部品が表示される発信元操作領域 5 2 0 3と、 出力先の装置に対して操作を行うための G U 丨部品が表示される 出力先操作領域 5 2 0 5と、 が設けられる。 図示する例では、 発信元操作領 域 5 2 0 3には、 撮像機能を有する発信元の装置におけるカメラに対して各 種の操作 (パン、 チルト及びズーム) を行うための G U 丨部品が設けられて いる。 ユーザは、 これらの G U 丨部品を適宜選択することにより、 発信元の 装置におけるカメラの動作を操作することができる。 なお、 図示は省略して \¥02020/174865 41 卩(:170?2019/050965 [0187] The control area 5201 is a source operation area 5203 that displays GUI (Graphical User Interface) parts for operating the source device and the output destination. An output destination operation area 5205 for displaying GU parts for operating the device is provided. In the example shown in the figure, the sender operation area 5203 is equipped with GU parts for performing various operations (pan, tilt, and zoom) on the camera of the sender device having an imaging function. It has been done. The user can operate the operation of the camera in the transmission source device by appropriately selecting these GU parts. The illustration is omitted. \¥02020/174865 41 卩 (: 170?2019/050965
いるが、 発信元選択領域 5 1 9 5において選択されている発信元の装置がレ コーダである場合 (すなわち、 プレビュー領域 5 1 9 7において、 レコーダ に過去に記録された画像が表示されている場合) には、 発信元操作領域 5 2 0 3には、 当該画像の再生、 再生停止、 巻き戻し、 早送り等の操作を行うた 丨部品が設けられ得る。 However, if the source device selected in the source selection area 5 195 is a recorder (that is, in the preview area 5 197, an image recorded in the past is displayed on the recorder). In the case), the sender operation area 520 3 may be provided with a part for performing operations such as reproduction, stop reproduction, rewind, and fast forward of the image.
[0188] また、 出力先操作領域 5 2 0 5には、 出力先の装置である表示装置におけ る表示に対する各種の操作 (スワップ、 フリップ、 色調整、 コントラスト調 整、 2 0表示と 3 0表示の切り替え) を行うための

[0189] なお、 集中操作パネル 5 1 1 1 に表示される操作画面は図示する例に限定 されず、 ユーザは、 集中操作パネル 5 1 1 1 を介して、 手術室システム 5 1 0 0に備えられる、 視聴覚コントローラ 5 1 0 7及び手術室制御装置 5 1 0 9によって制御され得る各装置に対する操作入力が可能であってよい。 [0189] The operation screen displayed on the centralized operation panel 5 1 1 1 is not limited to the example shown in the figure, and the user can prepare for the operating room system 5 1 0 0 via the centralized operation panel 5 1 1 1. It may be possible to input an operation to each device that can be controlled by the audiovisual controller 5107 and the operating room control device 5109.
[0190] 図 1 4は、 以上説明した手術室システムが適用された手術の様子の一例を 示す図である。 シーリングカメラ 5 1 8 7及び術場カメラ 5 1 8 9は、 手術 室の天井に設けられ、 患者ベッ ド 5 1 8 3上の患者 5 1 8 5の患部に対して 処置を行う術者 (医者) 5 1 8 1の手元及び手術室全体の様子を撮影可能で ある。 シーリングカメラ 5 1 8 7及び術場カメラ 5 1 8 9には、 倍率調整機 能、 焦点距離調整機能、 撮影方向調整機能等が設けられ得る。 照明 5 1 9 1 は、 手術室の天井に設けられ、 少なくとも術者 5 1 8 1の手元を照射する。 照明 5 1 9 1は、 その照射光量、 照射光の波長 (色) 及び光の照射方向等を 適宜調整可能であってよい。 [0190] Fig. 14 is a diagram showing an example of a state of surgery to which the operating room system described above is applied. The ceiling camera 5 1 8 7 and the operating room camera 5 1 8 9 are provided on the ceiling of the operating room and are used by a surgeon (doctor) who performs treatment on the affected area of the patient 5 1 8 5 on the patient bed 5 1 8 3. ) It is possible to take a picture of the condition of the hand and the entire operating room. The ceiling camera 518 and the operating room camera 518 may be provided with a magnification adjusting function, a focal length adjusting function, a photographing direction adjusting function, and the like. The lighting 5 1 9 1 is installed on the ceiling of the operating room and illuminates at least the hand of the operator 5 1 8 1. The illumination 519 1 may be capable of appropriately adjusting the amount of irradiation light, the wavelength (color) of irradiation light, the irradiation direction of light, and the like.
[0191 ] 内視鏡手術システム 5 1 1 3、 患者べッ ド 5 1 8 3、 シーリングカメラ 5 [0191] Endoscopic surgery system 5 1 1 3, patient bed 5 1 8 3, ceiling camera 5
1 8 7、 術場カメラ 5 1 8 9及び照明 5 1 9 1は、 図 1 2に示すように、 視 聴覚コントローラ 5 1 0 7及び手術室制御装置 5 1 0 9 (図 1 4では図示せ ず) を介して互いに連携可能に接続されている。 手術室内には、 集中操作パ ネル 5 1 1 1が設けられており、 上述したように、 ユーザは、 当該集中操作 \¥02020/174865 42 卩(:170?2019/050965 As shown in FIG. 12, the visual field auditory controller 5107 and the operating room controller 5109 (not shown in FIG. No.) are connected so that they can cooperate with each other. A centralized operation panel 5 1 1 1 1 is provided in the operating room. \¥02020/174865 42 卩 (: 170?2019/050965
パネル 5 1 1 1 を介して、 手術室内に存在するこれらの装置を適宜操作する ことが可能である。 It is possible to appropriately operate these devices existing in the operating room through the panel 5 1 1 1.
[0192] 以下、 内視鏡手術システム 5 1 1 3の構成について詳細に説明する。 図示 するように、 内視鏡手術システム 5 1 1 3は、 内視鏡 5 1 1 5と、 その他の 術具 5 1 3 1 と、 内視鏡 5 1 1 5を支持する支持アーム装置 5 1 4 1 と、 内 視鏡下手術のための各種の装置が搭載された力一卜 5 1 5 1 と、 から構成さ れる。 [0192] Hereinafter, the configuration of the endoscopic surgery system 5 1 1 3 will be described in detail. As shown in the figure, the endoscopic surgery system 5 1 1 3 includes an endoscope 5 1 1 5 and other surgical tools 5 1 3 1 and a support arm device 5 1 that supports the endoscope 5 1 1 5. 4 1 and a force unit 5 1 5 1 equipped with various devices for endoscopic surgery.
[0193] 内視鏡手術では、 腹壁を切って開腹する代わりに、 トロッカ 5 1 393〜 [0193] In endoscopic surgery, instead of cutting the abdominal wall to open the abdomen, trocar 5 1 39 3 ~
5 1 39 と呼ばれる筒状の開孔器具が腹壁に複数穿刺される。 そして、 卜 ロッカ 5 1 393~5 1 39 から、 内視鏡 5 1 1 5の鏡筒 5 1 1 7や、 そ の他の術具 5 1 3 1が患者 5 1 85の体腔内に挿入される。 図示する例では 、 その他の術具 5 1 3 1 として、 気腹チューブ 5 1 33、 エネルギー処置具 5 1 35及び鉗子 5 1 37が、 患者 5 1 85の体腔内に挿入されている。 ま た、 エネルギー処置具 5 1 35は、 高周波電流や超音波振動により、 組織の 切開及び剥離、 又は血管の封止等を行う処置具である。 ただし、 図示する術 *5 1 3 1はあくまで一例であり、 術具 5 1 3 1 としては、 例えば攝子、 レ トラクタ等、 一般的に内視鏡下手術において用いられる各種の術具が用いら れてよい。 A plurality of tubular openers called 5 1 39 are punctured in the abdominal wall. Then, the lens barrel 5 1 1 3 of the endoscope 5 1 1 5 and other surgical tools 5 1 3 1 are inserted into the body cavity of the patient 5 1 8 5 from the rocker lockers 5 1 39 3 to 5 1 39. It In the example shown in the figure, a pneumoperitoneum tube 5 133, an energy treatment tool 5 1 35 and forceps 5 1 37 are inserted into the body cavity of the patient 5 1 85 as other surgical tools 5 1 3 1. Further, the energy treatment tool 51-35 is a treatment tool for performing incision and separation of tissue, sealing of blood vessels, and the like by high-frequency current or ultrasonic vibration. However, the illustrated technique *5 1 3 1 is only an example, and various types of surgical instruments commonly used in endoscopic surgery such as a concussion and a retractor are used as the surgical instrument 5 13 1. You can
[0194] 内視鏡 5 1 1 5によって撮影された患者 5 1 85の体腔内の術部の画像が 、 表示装置 5 1 55に表示される。 術者 5 1 81は、 表示装置 5 1 55に表 示された術部の画像をリアルタイムで見ながら、 エネルギー処置具 5 1 35 や鉗子 5 1 37を用いて、 例えば患部を切除する等の処置を行う。 なお、 図 示は省略しているが、 気腹チューブ 5 1 33、 エネルギー処置具 5 1 35及 び鉗子 5 1 37は、 手術中に、 術者 5 1 81又は助手等によって支持される [0194] An image of the surgical site in the body cavity of the patient 5 1 85 taken by the endoscope 5 1 1 5 is displayed on the display device 5 1 55. The surgeon 5 1 81 uses the energy treatment tool 5 1 35 and forceps 5 1 37 while watching the image of the surgical site displayed on the display device 5 1 55 in real time, for example, to perform treatment such as excision of the affected area. I do. Although illustration is omitted, the pneumoperitoneum tube 5 1 33, the energy treatment tool 5 1 35, and the forceps 5 1 37 are supported by the operator 5 18 1 or an assistant or the like during the operation.
[0195] (支持アーム装置) [0195] (Support arm device)
支持アーム装置 5 1 4 1は、 ベース部 5 1 43から延伸するアーム部 5 1 45を備える。 図示する例では、 アーム部 5 1 45は、 関節部 5 1 473、 5 1 4 7 b、 5 1 4 7 c、 及びリンク 5 1 4 9 a、 5 1 4 9 bから構成され ており、 アーム制御装置 5 1 5 9からの制御により駆動される。 アーム部 5 1 4 5によって内視鏡 5 1 1 5が支持され、 その位置及び姿勢が制御される 。 これにより、 内視鏡 5 1 1 5の安定的な位置の固定が実現され得る。 The support arm device 5 1 4 1 includes an arm portion 5 1 45 extending from the base portion 5 1 43. In the example shown, the arm portion 5 1 45 is the joint portion 5 1 473, It is composed of 5 1 4 7 b, 5 1 4 7 c, and links 5 1 4 9 a and 5 1 4 9 b, and is driven by the control from the arm controller 5 1 5 9. The endoscope 5 1 1 5 is supported by the arm 5 1 4 5 and its position and posture are controlled. As a result, stable fixation of the endoscope 5115 can be realized.
[0196] (内視鏡) [0196] (Endoscope)
内視鏡 5 1 1 5は、 先端から所定の長さの領域が患者 5 1 8 5の体腔内に 揷入される鏡筒 5 1 1 7と、 鏡筒 5 1 1 7の基端に接続されるカメラヘッ ド 5 1 1 9と、 から構成される。 図示する例では、 硬性の鏡筒 5 1 1 7を有す るいわゆる硬性鏡として構成される内視鏡 5 1 1 5を図示しているが、 内視 鏡 5 1 1 5は、 軟性の鏡筒 5 1 1 7を有するいわゆる軟性鏡として構成され てもよい。 The endoscope 5 1 15 is connected to the lens barrel 5 1 1 7 where a region of a predetermined length from the distal end is inserted into the body cavity of the patient 5 1 8 5 and the proximal end of the lens barrel 5 1 1 7. It is composed of the camera head 5 1 1 9 and. In the example shown in the figure, the endoscope 5 1 15 that is configured as a so-called rigid endoscope having a rigid lens barrel 5 1 17 is shown, but the endoscope 5 1 15 is a flexible mirror. It may be configured as a so-called flexible mirror having a cylinder 5 117.
[0197] 鏡筒 5 1 1 7の先端には、 対物レンズが嵌め込まれた開口部が設けられて いる。 内視鏡 5 1 1 5には光源装置 5 1 5 7が接続されており、 当該光源装 置 5 1 5 7によって生成された光が、 鏡筒 5 1 1 7の内部に延設されるライ トガイ ドによって当該鏡筒の先端まで導光され、 対物レンズを介して患者 5 1 8 5の体腔内の観察対象に向かって照射される。 なお、 内視鏡 5 1 1 5は 、 直視鏡であってもよいし、 斜視鏡又は側視鏡であってもよい。 [0197] An opening in which an objective lens is fitted is provided at the tip of the lens barrel 5 1 1 7. A light source device 5 1 5 7 is connected to the endoscope 5 1 15 and light generated by the light source device 5 1 5 7 is extended to the inside of the lens barrel 5 1 1 7. The light is guided to the tip of the lens barrel by the guide, and is irradiated toward the observation target in the body cavity of the patient 518 through the objective lens. It should be noted that the endoscope 5115 may be a direct-viewing endoscope, or a perspective or side-viewing endoscope.
[0198] カメラヘッ ド 5 1 1 9の内部には光学系及び撮像素子が設けられており、 観察対象からの反射光 (観察光) は当該光学系によって当該撮像素子に集光 される。 当該撮像素子によって観察光が光電変換され、 観察光に対応する電 気信号、 すなわち観察像に対応する画像信号が生成される。 当該画像信号は 、 R A Wデータとしてカメラコントロールユニッ ト (C C U : Camera Cont r o l Un i t) 5 1 5 3に送信される。 なお、 カメラヘッ ド 5 1 1 9には、 その 光学系を適宜駆動させることにより、 倍率及び焦点距離を調整する機能が搭 載される。 [0198] An optical system and an image pickup device are provided inside the camera head 511 and the reflected light (observation light) from the observation target is focused on the image pickup device by the optical system. The observation light is photoelectrically converted by the imaging device, and an electric signal corresponding to the observation light, that is, an image signal corresponding to the observation image is generated. The image signal is sent to the camera control unit (CCU: Camera Control Unit) 5 1 5 3 as R A W data. The camera head 511 is equipped with a function to adjust the magnification and focal length by appropriately driving the optical system.
[0199] なお、 例えば立体視 (3 D表示) 等に対応するために、 カメラヘッ ド 5 1 [0199] Note that, for example, to support stereoscopic viewing (3D display), etc., the camera head 5 1
1 9には撮像素子が複数設けられてもよい。 この場合、 鏡筒 5 1 1 7の内部 には、 当該複数の撮像素子のそれぞれに観察光を導光するために、 リレー光 学系が複数系統設けられる。 A plurality of image pickup devices may be provided in 19. In this case, the relay light is introduced inside the lens barrel 5 1 1 1 7 in order to guide the observation light to each of the plurality of image pickup elements. There are multiple academic systems.
[0200] (力一卜に搭載される各種の装置) [0200] (Various devices installed in one unit)
CCU 5 1 53は、 C P U (Central Processing Unit) や G P U (Grap hies Processing Unit) 等によって構成され、 内視鏡 5 1 1 5及び表示装 置 5 1 55の動作を統括的に制御する。 具体的には、 CCU 5 1 53は、 力 メラへッ ド 5 1 1 9から受け取った画像信号に対して、 例えば現像処理 (デ モザイク処理) 等の、 当該画像信号に基づく画像を表示するための各種の画 像処理を施す。 CCU 5 1 53 、 当該画像処理を施した画像信号を表示装 置 5 1 55に提供する。 また、 〇〇115 1 53には、 図 1 2に示す視聴覚コ ントローラ 5 1 07が接続される。 CCU 5 1 53は、 画像処理を施した画 像信号を視聴覚コントローラ 5 1 07にも提供する。 また、 CCU 5 1 53 は、 カメラヘッ ド 5 1 1 9に対して制御信号を送信し、 その駆動を制御する 。 当該制御信号には、 倍率や焦点距離等、 撮像条件に関する情報が含まれ得 る。 当該撮像条件に関する情報は、 入力装置 5 1 6 1 を介して入力されても よいし、 上述した集中操作パネル 5 1 1 1 を介して入力されてもよい。 The CCU 515 is composed of a CPU (Central Processing Unit), a GPU (Graphics Processing Unit), and the like, and integrally controls the operations of the endoscope 5115 and the display device 515. Specifically, the CCU 5 1 53 displays an image based on the image signal, such as development processing (demosaic processing), on the image signal received from the camera head 5 1 19. Various image processing of. The CCU 5 1 53 provides the image signal subjected to the image processing to the display device 5 1 55. Also, the audiovisual controller 5107 shown in FIG. 12 is connected to the ◯115115. The CCU 5 1 53 also provides the image signal subjected to the image processing to the audiovisual controller 5 107. The CCU 5 1 53 also sends a control signal to the camera head 5 1 19 to control its drive. The control signal may include information regarding imaging conditions such as magnification and focal length. The information regarding the imaging condition may be input via the input device 5 1 61 or the above-described centralized operation panel 5 1 1 1.
[0201] 表示装置 5 1 55は、 CC U 5 1 53からの制御により、 当該 CCU 5 1 [0201] The display device 5 1 55 is controlled by the CC U 5 1 53, and the CCU 5 1 5
53によって画像処理が施された画像信号に基づく画像を表示する。 内視鏡 5 1 1 5が例えば 4 K (水平画素数 3840 X垂直画素数 2 1 60) 又は 8 K (水平画素数 7680 X垂直画素数 4320) 等の高解像度の撮影に対応 したものである場合、 及び/又は 3 D表示に対応したものである場合には、 表示装置 5 1 55としては、 それぞれに対応して、 高解像度の表示が可能な もの、 及び/又は 3 D表示可能なものが用いられ得る。 4 K又は 8 K等の高 解像度の撮影に対応したものである場合、 表示装置 5 1 55として 55イン チ以上のサイズのものを用いることで一層の没入感が得られる。 また、 用途 に応じて、 解像度、 サイズが異なる複数の表示装置 5 1 55が設けられても よい。 An image based on the image signal subjected to the image processing by 53 is displayed. The endoscope 5 1 1 5 is compatible with high-resolution shooting such as 4 K (horizontal pixel number 3840 x vertical pixel number 2 1 60) or 8 K (horizontal pixel number 7680 x vertical pixel number 4320). , And/or 3D display, the display device 5 1 55 is capable of high-resolution display and/or 3D display. Can be used. If the device is compatible with high-resolution shooting such as 4 K or 8 K, a more immersive feeling can be obtained by using a display device 5 1 55 having a size of 55 inches or more. Further, a plurality of display devices 5 1 55 having different resolutions and sizes may be provided depending on the application.
[0202] 光源装置 5 1 57は、 例えば L E D (Ught emitting diode) 等の光源 から構成され、 術部を撮影する際の照射光を内視鏡 5 1 1 5に供給する。 [0203] アーム制御装置 5 1 5 9は、 例えば C P U等のプロセッサによって構成さ れ、 所定のプログラムに従って動作することにより、 所定の制御方式に従っ て支持アーム装置 5 1 4 1のアーム部 5 1 4 5の駆動を制御する。 [0202] The light source device 5 1 57 is composed of a light source such as an LED (Ught emitting diode), and supplies the endoscope 5 1 15 with irradiation light for photographing the operation part. [0203] The arm control device 5 1 5 9 is composed of, for example, a processor such as a CPU, and operates according to a predetermined program, so that the arm portion 5 1 of the support arm device 5 1 4 1 follows a predetermined control method. Control the drive of 4 5.
[0204] 入力装置 5 1 6 1は、 内視鏡手術システム 5 1 1 3に対する入カインタフ ェースである。 ユーザは、 入力装置 5 1 6 1 を介して、 内視鏡手術システム 5 1 1 3に対して各種の情報の入力や指示入力を行うことができる。 例えば 、 ユーザは、 入力装置 5 1 6 1 を介して、 患者の身体情報や、 手術の術式に ついての情報等、 手術に関する各種の情報を入力する。 また、 例えば、 ユー ザは、 入力装置 5 1 6 1 を介して、 アーム部 5 1 4 5を駆動させる旨の指示 や、 内視鏡 5 1 1 5による撮像条件 (照射光の種類、 倍率及び焦点距離等) を変更する旨の指示、 エネルギー処置具 5 1 3 5を駆動させる旨の指示等を 入力する。 [0204] The input device 5 16 1 is an input interface to the endoscopic surgery system 5 1 13. The user can input various information and instructions to the endoscopic surgery system 5 1 1 3 via the input device 5 16 1. For example, the user inputs various kinds of information related to the surgery, such as the physical information of the patient and the information about the surgical procedure through the input device 5 16 1. In addition, for example, the user may give an instruction to drive the arm unit 5 1 45 via the input device 5 1 6 1, and the imaging conditions (type of irradiation light, magnification and magnification) of the endoscope 5 1 15. Input the instruction to change the focal length, etc.) and the instruction to drive the energy treatment tool 5 1 3 5.
[0205] 入力装置 5 1 6 1の種類は限定されず、 入力装置 5 1 6 1は各種の公知の 入力装置であってよい。 入力装置 5 1 6 1 としては、 例えば、 マウス、 キー ボード、 タッチパネル、 スイッチ、 フッ トスイッチ 5 1 7 1及び/又はレバ 一等が適用され得る。 入力装置 5 1 6 1 としてタッチパネルが用いられる場 合には、 当該タッチパネルは表示装置 5 1 5 5の表示面上に設けられてもよ い。 [0205] The type of the input device 5 16 1 is not limited, and the input device 5 16 1 may be various known input devices. As the input device 5 16 1, for example, a mouse, a keyboard, a touch panel, a switch, a foot switch 5 17 1 and/or a lever can be applied. When a touch panel is used as the input device 5 1 61, the touch panel may be provided on the display surface of the display device 5 1 5 5.
[0206] あるいは、 入力装置 5 1 6 1は、 例えばメガネ型のウェアラブルデバイス や H M D (Head Mounted D i sp lay) 等の、 ユーザによって装着されるデバ イスであり、 これらのデバイスによって検出されるユーザのジェスチヤや視 線に応じて各種の入力が行われる。 また、 入力装置 5 1 6 1は、 ユーザの動 きを検出可能なカメラを含み、 当該カメラによって撮像された映像から検出 されるユーザのジェスチヤや視線に応じて各種の入力が行われる。 更に、 入 力装置 5 1 6 1は、 ユーザの声を収音可能なマイクロフォンを含み、 当該マ イクロフォンを介して音声によって各種の入力が行われる。 このように、 入 力装置 5 1 6 1が非接触で各種の情報を入力可能に構成されることにより、 特に清潔域に属するユーザ (例えば術者 5 1 8 1) が、 不潔域に属する機器 \¥02020/174865 46 卩(:170?2019/050965 [0206] Alternatively, the input device 5 16 1 is a device worn by a user, such as a wearable device of a glasses type or a head mounted display (HMD), and a user detected by these devices. Various inputs are made according to the gesture and the line of sight. In addition, the input device 5 16 1 includes a camera capable of detecting the movement of the user, and various inputs are performed according to the user's gesture or line of sight detected from the image captured by the camera. Further, the input device 516 1 includes a microphone capable of collecting the user's voice, and various inputs are performed by voice through the microphone. In this way, the input device 5 16 1 is configured to be able to input various kinds of information in a contactless manner, so that a user who belongs to a clean area (for example, a surgeon 5 1 8 1) is a device that belongs to a dirty area. \¥02020/174865 46 卩 (: 170?2019/050965
を非接触で操作することが可能となる。 また、 ユーザは、 所持している術具 から手を離すことなく機器を操作することが可能となるため、 ユーザの利便 性が向上する。 Can be operated without contact. In addition, the user can operate the device without releasing his/her hand from the surgical tool, which improves the convenience of the user.
[0207] 処置具制御装置 5 1 63は、 組織の焼灼、 切開又は血管の封止等のための エネルギー処置具 5 1 35の駆動を制御する。 気腹装置 5 1 65は、 内視鏡 5 1 1 5による視野の確保及び術者の作業空間の確保の目的で、 患者 5 1 8 5の体腔を膨らめるために、 気腹チューブ 5 1 33を介して当該体腔内にガ スを送り込む。 レコーダ 5 1 67は、 手術に関する各種の情報を記録可能な 装置である。 プリンタ 5 1 69は、 手術に関する各種の情報を、 テキスト、 画像又はグラフ等各種の形式で印刷可能な装置である。 [0207] The treatment instrument control device 5 1 63 controls the drive of the energy treatment instrument 5 1 35 for cauterization of tissue, incision, sealing of blood vessels, and the like. The pneumoperitoneum device 5 1 65 is used to expand the body cavity of the patient 5 1 8 5 for the purpose of securing a visual field by the endoscope 5 1 15 and a working space for the operator. 1 Inject gas into the body cavity through 33. The recorder 5 1 67 is a device that can record various information related to surgery. The printer 5 169 is a device capable of printing various information regarding surgery in various formats such as text, images, and graphs.
[0208] 以下、 内視鏡手術システム 5 1 1 3において特に特徴的な構成について、 更に詳細に説明する。 [0208] Hereinafter, a particularly characteristic configuration of the endoscopic surgery system 5 1 1 3 will be described in more detail.
[0209] (支持アーム装置) [0209] (Support arm device)
支持アーム装置 5 1 4 1は、 基台であるべース部 5 1 43と、 ベース部 5 1 43から延伸するアーム部 5 1 45と、 を備える。 図示する例では、 アー ム部 5 1 45は、 複数の関節部 5 1 473、 5 1 47 5 1 47。と、 関 節部 5 1 47匕によって連結される複数のリンク 5 1 493、 5 1 49匕と 、 から構成されているが、 図 1 4では、 簡単のため、 アーム部 5 1 45の構 成を簡略化して図示している。 実際には、 アーム部 5 1 45が所望の自由度 を有するように、 関節部 5 1 473〜5 1 47〇及びリンク 5 1 493、 5 1 49匕の形状、 数及び配置、 並びに関節部 5 1 473~5 1 47〇の回転 軸の方向等が適宜設定され得る。 例えば、 アーム部 5 1 45は、 好適に、 6 自由度以上の自由度を有するように構成され得る。 これにより、 アーム部 5 1 45の可動範囲内において内視鏡 5 1 1 5を自由に移動させることが可能 になるため、 所望の方向から内視鏡 5 1 1 5の鏡筒 5 1 1 7を患者 5 1 85 の体腔内に揷入することが可能になる。 The support arm device 5 1 41 includes a base portion 5 1 43 which is a base and an arm portion 5 1 45 extending from the base portion 5 1 43. In the example shown, the arm section 5 1 45 is composed of multiple joint sections 5 1 473, 5 1 47 5 1 47. , And a plurality of links 5 1 493, 5 1 49, which are connected by the joint 5 1 47 arm, but in FIG. 14 the arm portion 5 1 45 is composed for simplification. Are simplified and illustrated. In practice, the shape, number and arrangement of the joints 5 1 47 3 to 5 1 47 0 and the links 5 1 493, 5 1 49, and the joints so that the arm 5 1 45 has a desired degree of freedom. The direction of the rotation axis of 5 1 47 3 to 5 1 47 〇 can be appropriately set. For example, the arm portion 145 may suitably be configured to have 6 or more degrees of freedom. This enables the endoscope 5 1 15 to move freely within the movable range of the arm 5 1 45, so that the lens barrel 5 1 1 7 of the endoscope 5 1 1 5 can be moved from a desired direction. Can be inserted into the body cavity of the patient 5 1 85.
[0210] 関節部 5 1 473~5 1 47〇にはアクチュエータが設けられており、 関 節部 5 1 473~5 1 47〇は当該アクチュエータの駆動により所定の回転 \¥02020/174865 47 卩(:170?2019/050965 [0210] An actuator is provided in the joint part 5 1 47 3 to 5 1 47 〇, and the joint part 5 1 47 3 to 5 1 47 〇 rotates in accordance with the drive of the actuator. \¥02020/174865 47 卩 (: 170?2019/050965
軸まわりに回転可能に構成されている。 当該アクチユエータの駆動がアーム 制御装置 5 1 5 9によって制御されることにより、 各関節部 5 1 4 7 3 ~ 5 1 4 7〇の回転角度が制御され、 アーム部 5 1 4 5の駆動が制御される。 こ れにより、 内視鏡 5 1 1 5の位置及び姿勢の制御が実現され得る。 この際、 アーム制御装置 5 1 5 9は、 力制御又は位置制御等、 各種の公知の制御方式 によってアーム部 5 1 4 5の駆動を制御することができる。 It is configured to be rotatable around an axis. The drive of the actuator is controlled by the arm controller 5 15 9 to control the rotation angles of the joints 5 1 4 7 3 to 5 1 4 7 0 and control the drive of the arm 5 1 4 5. To be done. With this, control of the position and posture of the endoscope 5115 can be realized. At this time, the arm controller 5 159 can control the drive of the arm 5 14 5 by various known control methods such as force control or position control.
[021 1 ] 例えば、 術者 5 1 8 1が、 入力装置 5 1 6 1 (フッ トスイッチ 5 1 7 1 を 含む) を介して適宜操作入力を行うことにより、 当該操作入力に応じてアー ム制御装置 5 1 5 9によってアーム部 5 1 4 5の駆動が適宜制御され、 内視 鏡 5 1 1 5の位置及び姿勢が制御されてよい。 当該制御により、 アーム部 5 1 4 5の先端の内視鏡 5 1 1 5を任意の位置から任意の位置まで移動させた 後、 その移動後の位置で固定的に支持することができる。 なお、 アーム部 5 1 4 5は、 いわゆるマスタースレイブ方式で操作されてもよい。 この場合、 アーム部 5 1 4 5は、 手術室から離れた場所に設置される入力装置 5 1 6 1 を介してユーザによって遠隔操作され得る。 [021 1] For example, the surgeon 5 1 8 1 makes an appropriate operation input via the input device 5 1 6 1 (including the foot switch 5 1 7 1), and the arm 5 The controller 5 1 5 9 may appropriately control the driving of the arm 5 1 4 5 to control the position and posture of the endoscope 5 1 1 5. By this control, the endoscope 5 1 15 at the tip of the arm 5 14 5 can be moved from any position to any position and then fixedly supported at the position after the movement. It should be noted that the arm portions 5145 may be operated by a so-called master slave method. In this case, the arm unit 5 1 4 5 can be remotely operated by the user via the input device 5 1 6 1 installed at a place apart from the operating room.
[0212] また、 力制御が適用される場合には、 アーム制御装置 5 1 5 9は、 ユーザ からの外力を受け、 その外力にならってスムーズにアーム部 5 1 4 5が移動 するように、 各関節部 5 1 4 7 3 ~ 5 1 4 7〇のアクチユエータを駆動させ る、 いわゆるパワーアシスト制御を行ってもよい。 これにより、 ユーザが直 接アーム部 5 1 4 5に触れながらアーム部 5 1 4 5を移動させる際に、 比較 的軽い力で当該アーム部 5 1 4 5を移動させることができる。 従って、 より 直感的に、 より簡易な操作で内視鏡 5 1 1 5を移動させることが可能となり 、 ユーザの利便性を向上させることができる。 [0212] Further, when force control is applied, the arm control device 5 1 5 9 receives an external force from the user, and the arm portion 5 1 4 5 moves smoothly in accordance with the external force. each joint 5 1 4 7 3-5 1 4 Ru by driving the actuator of 7_Rei may perform a so-called power assist control. Accordingly, when the user moves the arm unit 5 1 45 while directly touching the arm unit 5 1 45, the arm unit 5 1 45 can be moved with a comparatively light force. Therefore, the endoscope 5115 can be moved more intuitively and with a simpler operation, and the convenience for the user can be improved.
[0213] ここで、 一般的に、 内視鏡下手術では、 スコピストと呼ばれる医師によっ て内視鏡 5 1 1 5が支持されていた。 これに対して、 支持アーム装置 5 1 4 1 を用いることにより、 人手によらずに内視鏡 5 1 1 5の位置をより確実に 固定することが可能になるため、 術部の画像を安定的に得ることができ、 手 術を円滑に行うことが可能になる。 [0214] なお、 アーム制御装置 5 1 5 9は必ずしも力一卜 5 1 5 1 に設けられなく てもよい。 また、 アーム制御装置 5 1 5 9は必ずしも 1つの装置でなくても よい。 例えば、 アーム制御装置 5 1 5 9は、 支持アーム装置 5 1 4 1 のアー ム部 5 1 4 5の各関節部 5 1 4 7 a〜 5 1 4 7 cにそれぞれ設けられてもよ く、 複数のアーム制御装置 5 1 5 9が互いに協働することにより、 アーム部 5 1 4 5の駆動制御が実現されてもよい。 [0213] Here, in general, in endoscopic surgery, a doctor called a scopist supports the endoscope 5 115. On the other hand, by using the support arm device 5 1 41, it is possible to fix the position of the endoscope 5 1 1 5 more reliably without the need for manual labor, so that the image of the surgical site is stabilized. It is possible to obtain the desired results and to perform the procedure smoothly. [0214] Note that the arm control device 5 15 9 does not necessarily have to be provided in the force controller 5 1 5 1. Also, the arm control device 5 15 9 does not necessarily have to be one device. For example, the arm control device 5 1 5 9 may be provided in each joint part 5 1 4 7a to 5 1 4 7 c of the arm part 5 1 4 5 of the support arm device 5 1 4 1, respectively. The drive control of the arm units 5 1 4 5 may be realized by the plurality of arm control devices 5 1 5 9 cooperating with each other.
[0215] (光源装置) [0215] (Light source device)
光源装置 5 1 5 7は、 内視鏡 5 1 1 5に術部を撮影する際の照射光を供給 する。 光源装置 5 1 5 7は、 例えばLED、 レーザ光源又はこれらの組み合 わせによって構成される白色光源から構成される。 このとき、 RGBレーザ 光源の組み合わせにより白色光源が構成される場合には、 各色 (各波長) の 出力強度及び出カタイミングを高精度に制御することができるため、 光源装 置 5 1 5 7において撮像画像のホワイ トバランスの調整を行うことができる 。 また、 この場合には、 RG Bレーザ光源それぞれからのレーザ光を時分割 で観察対象に照射し、 その照射タイミングに同期してカメラへッ ド 5 1 1 9 の撮像素子の駆動を制御することにより、 R G Bそれぞれに対応した画像を 時分割で撮像することも可能である。 当該方法によれば、 当該撮像素子に力 ラーフイルタを設けなくても、 カラー画像を得ることができる。 The light source device 5 1 5 7 supplies the endoscope 5 1 1 5 with irradiation light for imaging the surgical site. The light source device 5 15 7 is composed of, for example, an LED, a laser light source, or a white light source configured by a combination thereof. At this time, when a white light source is configured by combining RGB laser light sources, the output intensity and output timing of each color (each wavelength) can be controlled with high accuracy, so the light source device 5 1 5 7 It is possible to adjust the white balance of the captured image. In this case, the laser light from each of the RGB laser light sources should be applied to the observation target in a time-division manner, and the drive of the image sensor of the camera head 5 1 1 9 should be controlled in synchronization with the irradiation timing. This makes it possible to capture images corresponding to each of RGB in time division. According to this method, a color image can be obtained without providing a force filter on the image sensor.
[0216] また、 光源装置 5 1 5 7は、 出力する光の強度を所定の時間ごとに変更す るようにその駆動が制御されてもよい。 その光の強度の変更のタイミングに 同期してカメラへッ ド 5 1 1 9の撮像素子の駆動を制御して時分割で画像を 取得し、 その画像を合成することにより、 いわゆる黒つぶれ及び白とびのな い高ダイナミックレンジの画像を生成することができる。 [0216] Further, the drive of the light source devices 5 1 5 7 may be controlled so as to change the intensity of the output light at predetermined time intervals. By controlling the drive of the image sensor of the camera head 5 1 1 9 in synchronism with the timing of changing the light intensity, images are acquired in a time-sharing manner, and the images are combined to create so-called blackout and white areas. It is possible to generate an image with a high dynamic range without breaks.
[0217] また、 光源装置 5 1 5 7は、 特殊光観察に対応した所定の波長帯域の光を 供給可能に構成されてもよい。 特殊光観察では、 例えば、 体組織における光 の吸収の波長依存性を利用して、 通常の観察時における照射光 (すなわち、 白色光) に比べて狭帯域の光を照射することにより、 粘膜表層の血管等の所 定の組織を高コントラストで撮影する、 いわゆる狭帯域光観察 (Nar row Ban d Imag i ng) が行われる。 あるいは、 特殊光観察では、 励起光を照射するこ とにより発生する蛍光により画像を得る蛍光観察が行われてもよい。 蛍光観 察では、 体組織に励起光を照射し当該体組織からの蛍光を観察するもの (自 家蛍光観察) 、 又はインドシアニングリーン (ICG) 等の試薬を体組織に局注 するとともに当該体組織にその試薬の蛍光波長に対応した励起光を照射し蛍 光像を得るもの等が行われ得る。 光源装置 5 1 5 7は、 このような特殊光観 察に対応した狭帯域光及び/又は励起光を供給可能に構成され得る。 [0217] Further, the light source devices 5 15 7 may be configured to be able to supply light in a predetermined wavelength band corresponding to special light observation. In the special light observation, for example, the wavelength dependence of the absorption of light in body tissues is used to irradiate a narrow band of light as compared with the irradiation light (that is, white light) at the time of normal observation. High-contrast imaging of certain tissues such as blood vessels in d Imag i ng) is performed. Alternatively, in the special light observation, fluorescence observation may be performed in which an image is obtained by fluorescence generated by irradiating the excitation light. In fluorescence observation, the body tissue is irradiated with excitation light to observe fluorescence from the body tissue (autofluorescence observation), or a reagent such as indocyanine green (ICG) is locally injected into the body tissue and the body tissue is injected. For example, the tissue may be irradiated with excitation light corresponding to the fluorescence wavelength of the reagent to obtain a fluorescent image. The light source device 5 15 7 can be configured to be able to supply the narrow band light and/or the excitation light corresponding to such special light observation.
[0218] (カメラヘッ ド及び C C U) [0218] (Camera head and C C U)
図 1 5を参照して、 内視鏡 5 1 1 5のカメラヘッ ド 5 1 1 9及び C C U 5 1 5 3の機能についてより詳細に説明する。 図 1 5は、 図 1 4に示すカメラ ヘッ ド 5 1 1 9及び C C U 5 1 5 3の機能構成の一例を示すブロック図であ る。 With reference to FIG. 15, the functions of the camera head 5 1 1 9 and the CCU 5 1 5 3 of the endoscope 5 1 1 5 will be described in more detail. FIG. 15 is a block diagram showing an example of the functional configuration of the camera head 511 and CCU 5153 shown in FIG.
[0219] 図 1 5を参照すると、 カメラへッ ド 5 1 1 9は、 その機能として、 レンズ ユニッ ト 5 1 2 1 と、 撮像部 5 1 2 3と、 駆動部 5 1 2 5と、 通信部 5 1 2 7と、 カメラヘッ ド制御部 5 1 2 9と、 を有する。 また、 C C U 5 1 5 3は 、 その機能として、 通信部 5 1 7 3と、 画像処理部 5 1 7 5と、 制御部 5 1 7 7と、 を有する。 カメラヘッ ド 5 1 1 9と C C U 5 1 5 3とは、 伝送ケー ブル 5 1 7 9によって双方向に通信可能に接続されている。 [0219] Referring to FIG. 15, the camera head 5 1 1 9 has, as its functions, a lens unit 5 1 2 1, an imaging unit 5 1 2 3, a driving unit 5 1 2 5 and a communication unit. It has a section 5 1 2 7 and a camera head control section 5 1 2 9. The CCU 5153 has, as its functions, a communication unit 5173, an image processing unit 5175, and a control unit 5177. The camera head 5 1 19 and the CCU 5 1 5 3 are connected by a transmission cable 5 1 7 9 so that they can communicate in both directions.
[0220] まず、 カメラヘッ ド 5 1 1 9の機能構成について説明する。 レンズユニッ 卜 5 1 2 1は、 鏡筒 5 1 1 7との接続部に設けられる光学系である。 鏡筒 5 1 1 7の先端から取り込まれた観察光は、 カメラへッ ド 5 1 1 9まで導光さ れ、 当該レンズユニッ ト 5 1 2 1 に入射する。 レンズユニッ ト 5 1 2 1は、 ズームレンズ及びフォーカスレンズを含む複数のレンズが組み合わされて構 成される。 レンズユニッ ト 5 1 2 1は、 撮像部 5 1 2 3の撮像素子の受光面 上に観察光を集光するように、 その光学特性が調整されている。 また、 ズー ムレンズ及びフォーカスレンズは、 撮像画像の倍率及び焦点の調整のため、 その光軸上の位置が移動可能に構成される。 [0220] First, the functional configuration of the camera head 5 1 1 9 will be described. The lens unit 5 1 2 1 is an optical system provided at a connection portion with the lens barrel 5 1 1 7. The observation light taken in from the tip of the lens barrel 5 1 1 7 is guided to the camera head 5 1 1 9 and enters the lens unit 5 1 2 1. The lens unit 5 1 2 1 is configured by combining a plurality of lenses including a zoom lens and a focus lens. The optical characteristics of the lens unit 5 1 2 1 are adjusted so that the observation light is condensed on the light receiving surface of the image pickup device of the image pickup unit 5 1 2 3. Further, the zoom lens and the focus lens are configured so that their positions on the optical axis can be moved in order to adjust the magnification and focus of the captured image.
[0221 ] 撮像部 5 1 2 3は撮像素子によって構成され、 レンズユニッ ト 5 1 2 1の 後段に配置される。 レンズユニッ ト 5 1 2 1 を通過した観察光は、 当該撮像 素子の受光面に集光され、 光電変換によって、 観察像に対応した画像信号が 生成される。 撮像部 5 1 2 3によって生成された画像信号は、 通信部 5 1 2 7に提供される。 [0221] The image pickup unit 5 1 2 3 is composed of an image pickup element, and the lens unit 5 1 2 1 It is placed in the latter stage. The observation light that has passed through the lens unit 5 1 2 1 is focused on the light-receiving surface of the image sensor, and photoelectric conversion generates an image signal corresponding to the observation image. The image signal generated by the imaging unit 5 1 2 3 is provided to the communication unit 5 1 2 7.
[0222] 撮像部 5 1 2 3を構成する撮像素子としては、 例えば C M O S (Comp lemen tary Meta l Ox i de Sem i conductor) タイプのイメージセンサであり、 B a y e r配列を有するカラー撮影可能なものが用いられる。 なお、 当該撮像素 子としては、 例えば 4 K以上の高解像度の画像の撮影に対応可能なものが用 いられてもよい。 術部の画像が高解像度で得られることにより、 術者 5 1 8 1は、 当該術部の様子をより詳細に把握することができ、 手術をより円滑に 進行することが可能となる。 [0222] As an image pickup device that constitutes the image pickup unit 5 1 2 3, for example, a CMOS (Complementary Metal Oxide de Sem i conductor) type image sensor, which has a Bayer array and is capable of color imaging, is used. Used. It should be noted that as the imaging element, for example, an imaging element that can be used to capture a high-resolution image of 4 K or more may be used. Since the image of the operative site is obtained with high resolution, the operator 518 1 can grasp the state of the operative site in more detail, and the operation can proceed more smoothly.
[0223] また、 撮像部 5 1 2 3を構成する撮像素子は、 3 D表示に対応する右目用 及び左目用の画像信号をそれぞれ取得するための 1対の撮像素子を有するよ うに構成される。 3 D表示が行われることにより、 術者 5 1 8 1は術部にお ける生体組織の奥行きをより正確に把握することが可能になる。 なお、 撮像 部 5 1 2 3が多板式で構成される場合には、 各撮像素子に対応して、 レンズ ユニッ ト 5 1 2 1 も複数系統設けられる。 [0223] Further, the image pickup device forming the image pickup unit 5 1 2 3 is configured to have a pair of image pickup devices for respectively acquiring image signals for the right eye and the left eye corresponding to 3D display. .. The 3D display enables the operator 5 18 1 to more accurately grasp the depth of the living tissue in the operation site. If the image pickup unit 5 1 2 3 is composed of a multi-plate type, a plurality of lens units 5 1 2 1 are provided corresponding to each image pickup device.
[0224] また、 撮像部 5 1 2 3は、 必ずしもカメラヘッ ド 5 1 1 9に設けられなく てもよい。 例えば、 撮像部 5 1 2 3は、 鏡筒 5 1 1 7の内部に、 対物レンズ の直後に設けられてもよい。 [0224] Further, the imaging unit 5 1 2 3 does not necessarily have to be provided in the camera head 5 1 1 9. For example, the imaging unit 5 1 2 3 may be provided inside the lens barrel 5 1 1 7 immediately after the objective lens.
[0225] 駆動部 5 1 2 5は、 ァクチユエータによって構成され、 カメラヘッ ド制御 部 5 1 2 9からの制御により、 レンズユニッ ト 5 1 2 1のズームレンズ及び フォーカスレンズを光軸に沿って所定の距離だけ移動させる。 これにより、 撮像部 5 1 2 3による撮像画像の倍率及び焦点が適宜調整され得る。 [0225] The drive unit 5 1 2 5 is composed of an actuator, and the zoom lens and the focus lens of the lens unit 5 1 2 1 are moved along the optical axis according to the control from the camera head control unit 5 1 2 9. Move only a distance. As a result, the magnification and focus of the imaged image by the imaging unit 5 1 2 3 can be adjusted appropriately.
[0226] 通信部 5 1 2 7は、 C C U 5 1 5 3との間で各種の情報を送受信するため の通信装置によって構成される。 通信部 5 1 2 7は、 撮像部 5 1 2 3から得 た画像信号を R A Wデータとして伝送ケーブル 5 1 7 9を介して C C U 5 1 5 3に送信する。 この際、 術部の撮像画像を低レイテンシで表示するために 、 当該画像信号は光通信によって送信されることが好ましい。 手術の際には 、 術者 5 1 8 1が撮像画像によって患部の状態を観察しながら手術を行うた め、 より安全で確実な手術のためには、 術部の動画像が可能な限りリアルタ イムに表示されることが求められるからである。 光通信が行われる場合には 、 通信部 5 1 2 7には、 電気信号を光信号に変換する光電変換モジュールが 設けられる。 画像信号は当該光電変換モジュールによって光信号に変換され た後、 伝送ケーブル 5 1 7 9を介して C C U 5 1 5 3に送信される。 The communication unit 5 1 2 7 is composed of a communication device for transmitting and receiving various kinds of information to and from the CCU 5 1 5 3. The communication unit 5 1 2 7 sends the image signal obtained from the imaging unit 5 1 2 3 as RAW data to the CCU 5 1 5 3 via the transmission cable 5 1 7 9. At this time, in order to display the captured image of the operative area with low latency, The image signal is preferably transmitted by optical communication. At the time of surgery, the operator 5181 performs the operation while observing the state of the affected area by the captured images, so for safer and more reliable surgery, the moving image of the operation area should be as realistic as possible. This is because it is required to be displayed on Im. When optical communication is performed, the communication unit 5 1 2 7 is provided with a photoelectric conversion module that converts an electric signal into an optical signal. The image signal is converted into an optical signal by the photoelectric conversion module, and then transmitted to the CCU 5 15 3 via the transmission cable 5 17 9.
[0227] また、 通信部 5 1 2 7は、 C C U 5 1 5 3から、 カメラヘッ ド 5 1 1 9の 駆動を制御するための制御信号を受信する。 当該制御信号には、 例えば、 撮 像画像のフレームレートを指定する旨の情報、 撮像時の露出値を指定する旨 の情報、 並びに/又は撮像画像の倍率及び焦点を指定する旨の情報等、 撮像 条件に関する情報が含まれる。 通信部 5 1 2 7は、 受信した制御信号をカメ ラへッ ド制御部 5 1 2 9に提供する。 なお、 C C U 5 1 5 3からの制御信号 も、 光通信によって伝送されてもよい。 この場合、 通信部 5 1 2 7には、 光 信号を電気信号に変換する光電変換モジュールが設けられ、 制御信号は当該 光電変換モジュールによって電気信号に変換された後、 カメラへッ ド制御部 5 1 2 9に提供される。 [0227] Also, the communication unit 5 1 2 7 receives a control signal for controlling the driving of the camera head 5 1 1 9 from the CCU 5 1 5 3. The control signal includes, for example, information that specifies the frame rate of the captured image, information that specifies the exposure value at the time of capturing, and/or information that specifies the magnification and focus of the captured image. It contains information about imaging conditions. The communication unit 5 1 2 7 provides the received control signal to the camera head control unit 5 1 2 9. The control signal from CCU 515 3 may also be transmitted by optical communication. In this case, the communication unit 5 1 2 7 is provided with a photoelectric conversion module that converts an optical signal into an electric signal, and the control signal is converted into an electric signal by the photoelectric conversion module and then the camera head control unit 5 Offered on 1 29.
[0228] なお、 上記のフレームレートや露出値、 倍率、 焦点等の撮像条件は、 取得 された画像信号に基づいて C C U 5 1 5 3の制御部 5 1 7 7によって自動的 に設定される。 つまり、 いわゆる A E (Auto Exposure) 機能、 A F (Auto Focus) 機能及び A W B (Auto Wh i te Ba lance) 機能が内視鏡 5 1 1 5に 搭載される。 [0228] Note that the imaging conditions such as the frame rate, the exposure value, the magnification, and the focus described above are automatically set by the control unit 5 1 7 7 of the CCU 5 15 3 based on the acquired image signal. That is, the so-called A E (Auto Exposure) function, A F (Auto Focus) function, and A W B (Auto White Balance) function are mounted on the endoscope 5 1 1 5.
[0229] カメラへッ ド制御部 5 1 2 9は、 通信部 5 1 2 7を介して受信した C C U [0229] The camera head control unit 5 1 2 9 receives the C C U received via the communication unit 5 1 2 7.
5 1 5 3からの制御信号に基づいて、 カメラヘッ ド 5 1 1 9の駆動を制御す る。 例えば、 カメラへッ ド制御部 5 1 2 9は、 撮像画像のフレームレートを 指定する旨の情報及び/又は撮像時の露光を指定する旨の情報に基づいて、 撮像部 5 1 2 3の撮像素子の駆動を制御する。 また、 例えば、 カメラヘッ ド 制御部 5 1 2 9は、 撮像画像の倍率及び焦点を指定する旨の情報に基づいて 、 駆動部 5 1 2 5を介してレンズユニッ ト 5 1 2 1のズームレンズ及びフォ —カスレンズを適宜移動させる。 カメラへッ ド制御部 5 1 2 9は、 更に、 鏡 筒 5 1 1 7やカメラヘッ ド 5 1 1 9を識別するための情報を記憶する機能を 備えてもよい。 The drive of the camera head 5 1 1 9 is controlled based on the control signal from 5 1 5 3. For example, the camera head control unit 5 1 2 9 may capture the image of the image capturing unit 5 1 2 3 based on the information indicating the frame rate of the captured image and/or the information indicating the exposure at the time of image capturing. Control the drive of the device. In addition, for example, the camera head control unit 5 1 2 9 sets the magnification and focus of the captured image based on the information to be specified. , The zoom lens and focus lens of the lens unit 5 1 2 1 are appropriately moved through the drive unit 5 1 2 5. The camera head controller 5 1 2 9 may further have a function of storing information for identifying the lens barrel 5 1 1 7 and the camera head 5 1 1 9.
[0230] なお、 レンズュニッ ト 5 1 2 1や撮像部 5 1 2 3等の構成を、 気密性及び 防水性が高い密閉構造内に配置することで、 カメラへッ ド 5 1 1 9について 、 オートクレープ滅菌処理に対する耐性を持たせることができる。 [0230] Note that by arranging the lens unit 5 1 2 1 and the image pickup unit 5 1 2 3 in a hermetically sealed structure that is highly airtight and waterproof, the camera head 5 1 1 9 can be automatically controlled. It can be made resistant to crepe sterilization.
[0231 ] 次に、 C C U 5 1 5 3の機能構成について説明する。 通信部 5 1 7 3は、 カメラヘッ ド 5 1 1 9との間で各種の情報を送受信するための通信装置によ って構成される。 通信部 5 1 7 3は、 カメラヘッ ド 5 1 1 9から、 伝送ケー ブル 5 1 7 9を介して送信される画像信号を受信する。 この際、 上記のよう に、 当該画像信号は好適に光通信によって送信され得る。 この場合、 光通信 に対応して、 通信部 5 1 7 3には、 光信号を電気信号に変換する光電変換モ ジュールが設けられる。 通信部 5 1 7 3は、 電気信号に変換した画像信号を 画像処理部 5 1 7 5に提供する。 [0231] Next, the functional configuration of the CCU 5153 will be described. The communication unit 5 17 3 is composed of a communication device for transmitting and receiving various kinds of information to and from the camera head 5 1 1 9. The communication section 5 17 3 receives the image signal transmitted from the camera head 5 1 19 via the transmission cable 5 1 7 9. At this time, as described above, the image signal can be preferably transmitted by optical communication. In this case, in correspondence with optical communication, the communication unit 5173 is provided with a photoelectric conversion module for converting an optical signal into an electric signal. The communication unit 5 17 3 provides the image signal converted to an electric signal to the image processing unit 5 17 5.
[0232] また、 通信部 5 1 7 3は、 カメラヘッ ド 5 1 1 9に対して、 カメラヘッ ド [0232] In addition, the communication unit 5 17 3 is different from the camera head 5 1 1 9 in that
5 1 1 9の駆動を制御するための制御信号を送信する。 当該制御信号も光通 信によって送信されてよい。 5 Sends a control signal to control the drive of 1 1 9. The control signal may also be transmitted by optical communication.
[0233] 画像処理部 5 1 7 5は、 カメラヘッ ド 5 1 1 9から送信された R A Wデー 夕である画像信号に対して各種の画像処理を施す。 当該画像処理としては、 例えば現像処理、 高画質化処理 (帯域強調処理、 超解像処理、 N R (No i se reduct i on) 処理及び/又は手ブレ補正処理等) 、 並びに/又は拡大処理 (電 子ズーム処理) 等、 各種の公知の信号処理が含まれる。 また、 画像処理部 5 1 7 5は、 A E、 A F及び A W Bを行うための、 画像信号に対する検波処理 を行う。 [0233] The image processing unit 5175 performs various types of image processing on the image signal which is the RA W data transmitted from the camera head 5 1 19. Examples of the image processing include development processing, high image quality processing (band enhancement processing, super-resolution processing, NR (Noise reduction) processing and/or camera shake correction processing), and/or enlargement processing ( Electronic zoom processing), and various other known signal processing are included. Further, the image processing unit 5175 performs detection processing on the image signal for performing A E, A F, and A W B.
[0234] 画像処理部 5 1 7 5は、 C P Uや G P U等のプロセッサによって構成され 、 当該プロセッサが所定のプログラムに従って動作することにより、 上述し た画像処理や検波処理が行われ得る。 なお、 画像処理部 5 1 7 5が複数の G \¥0 2020/174865 53 卩(:170?2019/050965 [0234] The image processing unit 5175 is composed of a processor such as a CPU and a GPU, and the image processing and detection processing described above can be performed by the processor operating according to a predetermined program. The image processing unit 5 1 7 5 has multiple G \¥0 2020/174865 53 卩 (: 170?2019/050965
IIによって構成される場合には、 画像処理部 5 1 7 5は、 画像信号に係る 情報を適宜分割し、 これら複数の◦ IIによって並列的に画像処理を行う。 When configured by II, the image processing unit 5175 appropriately divides information related to the image signal and performs image processing in parallel by the plurality of II.
[0235] 制御部 5 1 7 7は、 内視鏡 5 1 1 5による術部の撮像、 及びその撮像画像 の表示に関する各種の制御を行う。 例えば、 制御部 5 1 7 7は、 カメラへッ ド 5 1 1 9の駆動を制御するための制御信号を生成する。 この際、 撮像条件 がユーザによって入力されている場合には、 制御部 5 1 7 7は、 当該ユーザ による入力に基づいて制御信号を生成する。 あるいは、 内視鏡 5 1 1 5に八 巳機能、 機能及び 巳機能が搭載されている場合には、 制御部 5 1 7 7は、 画像処理部 5 1 7 5による検波処理の結果に応じて、 最適な露出値、 焦点距離及びホワイ トバランスを適宜算出し、 制御信号を生成する。 [0235] The control unit 5 17 7 carries out various controls relating to the imaging of the surgical site by the endoscope 5 1 15 and the display of the captured image. For example, the control unit 5 17 7 generates a control signal for controlling the driving of the camera head 5 1 1 7. At this time, when the imaging condition is input by the user, the control unit 517 7 generates a control signal based on the input by the user. Alternatively, when the endoscope 5 1 15 is equipped with the eight-axis function, the function, and the number-of-fault function, the control unit 5 1 7 7 controls the image processing unit 5 1 7 5 according to the detection processing result. , The optimum exposure value, focal length and white balance are calculated as appropriate, and the control signal is generated.
[0236] また、 制御部 5 1 7 7は、 画像処理部 5 1 7 5によって画像処理が施され た画像信号に基づいて、 術部の画像を表示装置 5 1 5 5に表示させる。 この 際、 制御部 5 1 7 7は、 各種の画像認識技術を用いて術部画像内における各 種の物体を認識する。 例えば、 制御部 5 1 7 7は、 術部画像に含まれる物体 のエッジの形状や色等を検出することにより、 鉗子等の術具、 特定の生体部 位、 出血、 エネルギー処置具 5 1 3 5使用時のミスト等を認識することがで きる。 制御部 5 1 7 7は、 表示装置 5 1 5 5に術部の画像を表示させる際に 、 その認識結果を用いて、 各種の手術支援情報を当該術部の画像に重畳表示 させる。 手術支援情報が重畳表示され、 術者 5 1 8 1 に提示されることによ り、 より安全かつ確実に手術を進めることが可能になる。 Further, the control unit 5 17 7 causes the display device 5 1 5 5 to display the image of the operation unit based on the image signal subjected to the image processing by the image processing unit 5 1 7 5. At this time, the control unit 517 recognizes each kind of object in the operative image by using various image recognition techniques. For example, the control unit 5 17 7 detects the shape and color of the edge of the object included in the surgical region image to determine the surgical instrument such as forceps, a specific living body part, bleeding, energy treatment device 5 1 3 5 It is possible to recognize the mist, etc. during use. When displaying the image of the operative site on the display device 515, the control unit 517 uses the recognition result to superimpose and display various types of surgical support information on the image of the operative site. By displaying the surgery support information in a superimposed manner and presenting it to the operator 5181, it becomes possible to proceed with the surgery more safely and reliably.
[0237] カメラヘッ ド 5 1

9は、 電気信号の通信に対応した電気信号ケ_ブル、 光通信に対応した光フ ァイバ、 又はこれらの複合ケーブルである。 9 is an electrical signal Ke _ Bull corresponding to the communication of electrical signals, light off Aiba corresponding to optical communication, or a composite cable.
[0238] ここで、 図示する例では、 伝送ケーブル 5 1 7 9を用いて有線で通信が行 われていたが、 カメラヘッ ド 5 1 1 9と〇〇11 5 1 5 3との間の通信は無線 で行われてもよい。 両者の間の通信が無線で行われる場合には、 伝送ケープ ル 5 1 7 9を手術室内に敷設する必要がなくなるため、 手術室内における医 療スタッフの移動が当該伝送ケーブル 5 1 7 9によって妨げられる事態が解 消され得る。 [0238] Here, in the example shown in the figure, wired communication was performed using the transmission cable 5179, but communication between the camera head 511 It may be performed wirelessly. If the communication between the two is performed wirelessly, it is not necessary to lay the transmission cable 5179 in the operating room, and therefore the movement of medical staff in the operating room is hindered by the transmission cable 5179. The situation is solved Can be erased.
[0239] 以上、 本開示に係る技術が適用され得る手術室システム 5 1 0 0の一例に ついて説明した。 なお、 ここでは、 一例として手術室システム 5 1 0 0が適 用される医療用システムが内視鏡手術システム 5 1 1 3である場合について 説明したが、 手術室システム 5 1 0 0の構成はかかる例に限定されない。 例 えば、 手術室システム 5 1 0 0は、 内視鏡手術システム 5 1 1 3に代えて、 検査用軟性内視鏡システムや顕微鏡手術システムに適用されてもよい。 [0239] The example of the operating room system 510 to which the technology according to the present disclosure can be applied has been described above. Here, as an example, the case where the medical system to which the operating room system 510 is applied is the endoscopic surgery system 5113 is explained. However, the configuration of the operating room system 510 is as follows. It is not limited to such an example. For example, the operating room system 5100 may be applied to a flexible endoscopic system for examination or a microscopic surgery system instead of the endoscopic surgery system 5113.
[0240] 本開示に係る技術は、 以上説明した構成のうち、 シーリングカメラ 5 1 8 [0240] The technique according to the present disclosure includes the ceiling camera 5 18 among the configurations described above.
7や術場カメラ 5 1 8 9や内視鏡に好適に適用され得る。 具体的には、 これ らのカメラや内視鏡である撮像装置及びこれらの撮像装置における可変焦点 距離レンズ系に適用され得る。 これらのカメラや内視鏡に本開示に係る技術 を適用することにより、 より鮮明な術部画像を得ることができる。 It can be suitably applied to a 7 or a surgical field camera 189 or an endoscope. Specifically, it can be applied to imaging devices such as these cameras and endoscopes, and variable focal length lens systems in these imaging devices. By applying the technology according to the present disclosure to these cameras and endoscopes, it is possible to obtain clearer images of the surgical site.
[0241 ] [応用例 2 ] [0241] [Application example 2]
本開示に係る技術は、 様々な製品へ応用することができる。 例えば、 本開 示に係る技術は、 自動車、 電気自動車、 ハイブリッ ド電気自動車、 自動二輪 車、 自転車、 パーソナルモビリティ、 飛行機、 ドローン、 船舶、 ロボッ ト、 建設機械、 農業機械 (トラクター) などのいずれかの種類の移動体に搭載さ れる撮像装置又は可変焦点距離レンズ系に適用されてもよい。 The technology according to the present disclosure can be applied to various products. For example, the technology related to this disclosure may be any of automobiles, electric vehicles, hybrid electric vehicles, motorcycles, bicycles, personal mobility, airplanes, drones, ships, robots, construction machinery, agricultural machinery (tractors), etc. It may be applied to an image pickup device or a variable focal length lens system mounted on a moving body of this type.
[0242] 図 1 6は、 本開示に係る技術が適用され得る移動体制御システムの一例で ある車両制御システム 7 0 0 0の概略的な構成例を示すブロック図である。 車両制御システム 7 0 0 0は、 通信ネッ トワーク 7 0 1 0を介して接続され た複数の電子制御ユニッ トを備える。 図 1 6に示した例では、 車両制御シス テム 7 0 0 0は、 駆動系制御ユニッ ト 7 1 0 0、 ボディ系制御ユニッ ト 7 2 0 0、 バッテリ制御ユニッ ト 7 3 0 0、 車外情報検出ユニッ ト 7 4 0 0、 車 内情報検出ユニッ ト 7 5 0 0、 及び統合制御ユニッ ト 7 6 0 0を備える。 こ れらの複数の制御ユニッ トを接続する通信ネッ トワーク 7 0 1 0は、 例えば 、 C A N (Cont ro I ler Area Network) 、 L I N (Loca l Interconnect N etwork) 、 L A N (Loca l Area Network) 又は F I e x R a y (登録商標 ) 等の任意の規格に準拠した車載通信ネッ トワークであってよい。 [0242] FIG. 16 is a block diagram showing a schematic configuration example of a vehicle control system 700 that is an example of a mobile body control system to which the technology according to the present disclosure can be applied. The vehicle control system 700 includes a plurality of electronic control units connected via a communication network 7100. In the example shown in Fig. 16, the vehicle control system 700 is a drive system control unit 7100, a body system control unit 7200, a battery control unit 7300, and vehicle exterior information. A detection unit 7400, an in-vehicle information detection unit 7500, and an integrated control unit 7600 are provided. A communication network for connecting these control units is, for example, CAN (Con troller Area Network), LIN (Local Interconnect Network), LAN (Local Area Network) or FI ex R ay (registered trademark ), etc., may be an in-vehicle communication network that complies with any standard.
[0243] 各制御ユニッ トは、 各種プログラムにしたがって演算処理を行うマイクロ コンビュータと、 マイクロコンピュータにより実行されるプログラム又は各 種演算に用いられるパラメータ等を記憶する記憶部と、 各種制御対象の装置 を駆動する駆動回路とを備える。 各制御ユニッ トは、 通信ネッ トワーク 70 1 0を介して他の制御ユニッ トとの間で通信を行うためのネッ トワーク 丨 / Fを備えるとともに、 車内外の装置又はセンサ等との間で、 有線通信又は無 線通信により通信を行うための通信丨 /Fを備える。 図 1 6では、 統合制御 ユニッ ト 7600の機能構成として、 マイクロコンピュータ 76 1 0、 汎用 通信 I /F 7620、 専用通信丨 /F 7630、 測位部 7640、 ビーコン 受信部 7650、 車内機器 I / F 7660、 音声画像出力部 7670、 車載 ネッ トワーク I /F 7680及び記憶部 7690が図示されている。 他の制 御ユニッ トも同様に、 マイクロコンピュータ、 通信丨 /F及び記憶部等を備 ス ·る。 [0243] Each control unit includes a microcomputer that performs arithmetic processing according to various programs, a storage unit that stores a program executed by a microcomputer or parameters used for various arithmetic operations, and devices to be controlled. And a drive circuit for driving. Each control unit is equipped with a network/F for communicating with other control units via the communication network 7010, and also with devices inside or outside the vehicle, sensors, etc. It is equipped with a communication system /F for performing communication by wire communication or wireless communication. In Fig. 16, the functional configuration of the integrated control unit 7600 is as follows: Microcomputer 7610, General-purpose communication I/F 7620, Dedicated communication I/F 7630, Positioning unit 7640, Beacon receiving unit 7650, In-vehicle device I/F 7660 The audio/video output unit 7670, the in-vehicle network I/F 7680, and the storage unit 7690 are illustrated. Similarly, the other control units are also equipped with a microcomputer, communication/F, and storage.
[0244] 駆動系制御ユニッ ト 7 1 00は、 各種プログラムにしたがって車両の駆動 系に関連する装置の動作を制御する。 例えば、 駆動系制御ユニッ ト 7 1 00 は、 内燃機関又は駆動用モータ等の車両の駆動力を発生させるための駆動力 発生装置、 駆動力を車輪に伝達するための駆動力伝達機構、 車両の舵角を調 節するステアリング機構、 及び、 車両の制動力を発生させる制動装置等の制 御装置として機能する。 駆動系制御ユニッ ト 7 1 00は、 A B S (Anti lock Brake System) 又は ESC (Electronic Stability Control) 等の制御 装置としての機能を有してもよい。 [0244] The drive system control unit 7100 controls the operation of devices related to the drive system of the vehicle according to various programs. For example, the drive system control unit 7100 is a drive force generation device for generating drive force of a vehicle such as an internal combustion engine or a drive motor, a drive force transmission mechanism for transmitting drive force to wheels, It functions as a steering mechanism that adjusts the steering angle and as a control device such as a braking device that generates the braking force of the vehicle. The drive system control unit 7100 may have a function as a control device such as an ABS (Anti lock Brake System) or an ESC (Electronic Stability Control).
[0245] 駆動系制御ユニッ ト 7 1 00には、 車両状態検出部 7 1 1 0が接続される 。 車両状態検出部 7 1 1 0には、 例えば、 車体の軸回転運動の角速度を検出 するジャイロセンサ、 車両の加速度を検出する加速度センサ、 あるいは、 ア クセルペダルの操作量、 ブレーキペダルの操作量、 ステアリングホイールの 操舵角、 エンジン回転数又は車輪の回転速度等を検出するためのセンサのう ちの少なくとも一つが含まれる。 駆動系制御ユニッ ト 7 1 00は、 車両状態 検出部 7 1 1 0から入力される信号を用いて演算処理を行い、 内燃機関、 駆 動用モータ、 電動パワーステアリング装置又はブレーキ装置等を制御する。 [0245] The vehicle state detection unit 711 is connected to the drive system control unit 710. The vehicle state detection unit 7 1 1 1 0 includes, for example, a gyro sensor that detects the angular velocity of the shaft rotational movement of the vehicle body, an acceleration sensor that detects the acceleration of the vehicle, or the operation amount of the axel pedal, the operation amount of the brake pedal, and the steering At least one of the sensors for detecting the steering angle of the wheel, the engine speed, the rotational speed of the wheel, etc. is included. The drivetrain control unit 7 100 is The arithmetic processing is performed by using the signal input from the detection unit 7110, and the internal combustion engine, the drive motor, the electric power steering device, the brake device, and the like are controlled.
[0246] ボディ系制御ユニッ ト 7 2 0 0は、 各種プログラムにしたがって車体に装 備された各種装置の動作を制御する。 例えば、 ボディ系制御ユニッ ト 7 2 0 0は、 キーレスエントリシステム、 スマートキーシステム、 パワーウインド ウ装置、 あるいは、 ヘッ ドランプ、 バックランプ、 ブレーキランプ、 ウィン 力一又はフォグランプ等の各種ランプの制御装置として機能する。 この場合 、 ボディ系制御ユニッ ト 7 2 0 0には、 鍵を代替する携帯機から発信される 電波又は各種スイッチの信号が入力され得る。 ボディ系制御ユニッ ト 7 2 0 0は、 これらの電波又は信号の入力を受け付け、 車両のドアロック装置、 パ ワーウィンドウ装置、 ランプ等を制御する。 [0246] The body system control unit 7200 controls the operation of various devices mounted on the vehicle body according to various programs. For example, the body system control unit 720 is used as a keyless entry system, smart key system, power window device, or as a control device for various lamps such as headlamps, back lamps, brake lamps, win-win or fog lights. Function. In this case, radio waves or signals from various switches transmitted from a portable device that substitutes for a key can be input to the body system control unit 700. The body system control unit 7200 receives these radio waves or signals and controls the vehicle door lock device, power window device, lamp, and the like.
[0247] バッテリ制御ユニッ ト 7 3 0 0は、 各種プログラムにしたがって駆動用モ —夕の電力供給源である二次電池 7 3 1 0を制御する。 例えば、 バッテリ制 御ユニッ ト 7 3 0 0には、 二次電池 7 3 1 0を備えたバッテリ装置から、 バ ッテリ温度、 バッテリ出力電圧又はバッテリの残存容量等の情報が入力され る。 バッテリ制御ユニッ ト 7 3 0 0は、 これらの信号を用いて演算処理を行 い、 二次電池 7 3 1 0の温度調節制御又はバッテリ装置に備えられた冷却装 置等の制御を行う。 [0247] The battery control unit 7300 controls the secondary battery 7310 that is a power supply source for the drive mode according to various programs. For example, information such as the battery temperature, the battery output voltage, or the remaining capacity of the battery is input to the battery control unit 7300 from the battery device including the secondary battery 7310. The battery control unit 7300 performs arithmetic processing using these signals to control the temperature of the secondary battery 7310 or the cooling device provided in the battery device.
[0248] 車外情報検出ユニッ ト 7 4 0 0は、 車両制御システム 7 0 0 0を搭載した 車両の外部の情報を検出する。 例えば、 車外情報検出ユニッ ト 7 4 0 0には 、 撮像部 7 4 1 〇及び車外情報検出部 7 4 2 0のうちの少なくとも一方が接 続される。 撮像部 7 4 1 0には、 T〇 F (T i me Of F l i ght) カメラ、 ステ レオカメラ、 単眼カメラ、 赤外線カメラ及びその他のカメラのうちの少なく とも一つが含まれる。 車外情報検出部 7 4 2 0には、 例えば、 現在の天候又 は気象を検出するための環境センサ、 あるいは、 車両制御システム 7 0 0 0 を搭載した車両の周囲の他の車両、 障害物又は歩行者等を検出するための周 囲情報検出センサのうちの少なくとも一つが含まれる。 [0248] The vehicle exterior information detection unit 740 detects information outside the vehicle equipped with the vehicle control system 7000. For example, at least one of the image pickup unit 7410 and the exterior information detection unit 7420 is connected to the exterior information detection unit 7400. The image capturing unit 741 includes at least one of a T F (T i Me Of F l i ght) camera, a stereo camera, a monocular camera, an infrared camera and other cameras. The vehicle exterior information detection unit 7420 includes, for example, an environment sensor for detecting the current weather or the weather, or another vehicle around the vehicle equipped with the vehicle control system 70000, an obstacle, or an obstacle. At least one of the surrounding information detection sensors for detecting a pedestrian or the like is included.
[0249] 環境センサは、 例えば、 雨天を検出する雨滴センサ、 霧を検出する霧セン サ、 日照度合いを検出する日照センサ、 及び降雪を検出する雪センサのうち の少なくとも一つであってよい。 周囲情報検出センサは、 超音波センサ、 レ —ダ装置及び L 丨 DAR (Light Detection and Ranging、 Laser I mag i n g Detection and Ranging) 装置のうちの少なくとも一つであってよい。 これらの撮像部 74 1 〇及び車外情報検出部 7420は、 それぞれ独立した センサないし装置として備えられてもよいし、 複数のセンサないし装置が統 合された装置として備えられてもよい。 [0249] The environment sensor is, for example, a raindrop sensor that detects rainy weather, or a fog sensor that detects fog. At least one of a sun sensor, a sun sensor that detects the degree of sunshine, and a snow sensor that detects snowfall. The ambient information detection sensor may be at least one of an ultrasonic sensor, a radar device, and a L DAR (Light Detection and Ranging, Laser Imaging Detection and Ranging) device. The image pickup unit 74 10 and the vehicle exterior information detection unit 7420 may be provided as independent sensors or devices, or may be provided as a device in which a plurality of sensors or devices are integrated.
[0250] ここで、 図 1 7は、 撮像部 74 1 0及び車外情報検出部 7420の設置位 置の例を示す。 撮像部 79 1 0, 79 1 2, 79 1 4, 79 1 6, 79 1 8 は、 例えば、 車両 7900のフロントノーズ、 サイ ドミラー、 リアバンパ、 バックドア及び車室内のフロントガラスの上部のうちの少なくとも一つの位 置に設けられる。 フロントノーズに備えられる撮像部 79 1 0及び車室内の フロントガラスの上部に備えられる撮像部 79 1 8は、 主として車両 790 〇の前方の画像を取得する。 サイ ドミラーに備えられる撮像部 79 1 2, 7 9 1 4は、 主として車両 7900の側方の画像を取得する。 リアバンパ又は バックドアに備えられる撮像部 79 1 6は、 主として車両 7900の後方の 画像を取得する。 車室内のフロントガラスの上部に備えられる撮像部 79 1 8は、 主として先行車両又は、 歩行者、 障害物、 信号機、 交通標識又は車線 等の検出に用いられる。 [0250] Here, Fig. 17 shows an example of the installation positions of the imaging unit 7410 and the vehicle exterior information detection unit 7420. The imaging unit 79 1 0, 79 1 2, 79 1 4, 79 1 6, 79 1 8 is, for example, at least one of the front nose of the vehicle 7900, the side mirror, the rear bumper, the back door, and the upper part of the windshield inside the vehicle. It is provided in one position. The image pickup unit 79 10 provided on the front nose and the image pickup unit 79 18 provided on the upper part of the windshield in the vehicle interior mainly acquire images in front of the vehicle 7900. The imaging unit 79 1 2, 7 9 14 provided in the side mirror mainly acquires an image of the side of the vehicle 7900. The image pickup unit 79 16 provided in the rear bumper or the back door mainly acquires an image of the rear of the vehicle 7900. The imaging unit 79 18 provided on the upper part of the windshield inside the vehicle is mainly used for detecting a preceding vehicle or a pedestrian, an obstacle, a traffic signal, a traffic sign or a lane.
[0251] なお、 図 1 7には、 それぞれの撮像部 79 1 0, 79 1 2, 79 1 4, 7 [0251] Note that in Fig. 17, the respective imaging units 79 1 0, 79 1 2, 79 1 4, 7
9 1 6の撮影範囲の一例が示されている。 撮像範囲 aは、 フロントノーズに 設けられた撮像部 79 1 0の撮像範囲を示し、 撮像範囲 b, cは、 それぞれ サイ ドミラーに設けられた撮像部 79 1 2, 79 1 4の撮像範囲を示し、 撮 像範囲 dは、 リアバンパ又はバックドアに設けられた撮像部 79 1 6の撮像 範囲を示す。 例えば、 撮像部 79 1 0, 79 1 2, 79 1 4, 79 1 6で撮 像された画像データが重ね合わせられることにより、 車両 7900を上方か ら見た俯瞰画像が得られる。 An example of a shooting range of 9 16 is shown. Imaging range a indicates the imaging range of the imaging unit 79 10 provided on the front nose, and imaging ranges b and c indicate the imaging range of the imaging units 79 1 2, 79 1 4 provided on the side mirrors, respectively. The image pickup range d indicates the image pickup range of the image pickup section 79 16 provided on the rear bumper or the back door. For example, by superimposing the image data taken by the imaging units 79 1 0, 79 1 2, 79 1 4, 79 16 on top of each other, a bird's-eye view of the vehicle 7900 from above can be obtained.
[0252] 車両 7900のフロント、 リア、 サイ ド、 コーナ及び車室内のフロントガ \¥02020/174865 58 卩(:170?2019/050965 [0252] Vehicle 7900 front, rear, side, corner, and front doors in the passenger compartment. \¥02020/174865 58 卩 (: 170?2019/050965
ラスの上部に設けられる車外情報検出部 7 9 2 0 , 7 9 2 2 , 7 9 2 4 , 7 9 2 6 , 7 9 2 8 , 7 9 3 0は、 例えば超音波センサ又はレーダ装置であっ てよい。 車両 7 9 0 0のフロントノーズ、 リアバンパ、 バックドア及び車室 内のフロントガラスの上部に設けられる車外情報検出部 7 9 2 0 , 7 9 2 6 , 7 9 3 0は、 例えば 1_ 丨 口八 装置であってよい。 これらの車外情報検出 部 7 9 2 0〜 7 9 3 0は、 主として先行車両、 歩行者又は障害物等の検出に 用いられる。 The vehicle exterior information detectors 7 9 2 0, 7 9 2 2, 7 9 2 4, 7 9 2 6, 7 9 2 8 and 7 9 30 provided on the top of the lath are, for example, ultrasonic sensors or radar devices. You may The vehicle exterior information detectors 7 9 2 0 ,7 9 2 6 ,7 9 3 0 provided on the front nose, rear bumper, back door and upper windshield of the vehicle 7900 are, for example, 1_ It may be a device. These outside-vehicle information detection units 7920 to 7930 are mainly used to detect a preceding vehicle, a pedestrian, an obstacle, or the like.
[0253] 図 1 6に戻って説明を続ける。 車外情報検出ユニッ ト 7 4 0 0は、 撮像部 [0253] Returning to FIG. 16 and continuing the explanation. The exterior information detection unit 7400 is
7 4 1 0に車外の画像を撮像させるとともに、 撮像された画像データを受信 する。 また、 車外情報検出ユニッ ト 7 4 0 0は、 接続されている車外情報検 出部 7 4 2 0から検出情報を受信する。 車外情報検出部 7 4 2 0が超音波セ ンサ、 レーダ装置又は !_ 丨 口 装置である場合には、 車外情報検出ユニッ 卜 7 4 0 0は、 超音波又は電磁波等を発信させるとともに、 受信された反射 波の情報を受信する。 車外情報検出ユニッ ト 7 4 0 0は、 受信した情報に基 づいて、 人、 車、 障害物、 標識又は路面上の文字等の物体検出処理又は距離 検出処理を行ってもよい。 車外情報検出ユニッ ト 7 4 0 0は、 受信した情報 に基づいて、 降雨、 霧又は路面状況等を認識する環境認識処理を行ってもよ い。 車外情報検出ユニッ ト 7 4 0 0は、 受信した情報に基づいて、 車外の物 体までの距離を算出してもよい。 The image of the outside of the vehicle is captured by the 7410, and the captured image data is received. The vehicle exterior information detection unit 7400 receives the detection information from the vehicle exterior information detection unit 7420 connected to the vehicle exterior information detection unit 7400. When the vehicle exterior information detection unit 7420 is an ultrasonic sensor, radar device or !_ 口口装置, the vehicle exterior information detection unit 7400 transmits ultrasonic waves or electromagnetic waves and receives them. Receives the reflected wave information. The vehicle exterior information detection unit 740 may perform object detection processing or distance detection processing such as people, vehicles, obstacles, signs, or characters on the road surface based on the received information. The exterior information detection unit 7400 may perform environment recognition processing for recognizing rainfall, fog, road surface conditions, etc. based on the received information. The vehicle exterior information detection unit 7400 may calculate the distance to an object outside the vehicle based on the received information.
[0254] また、 車外情報検出ユニッ ト 7 4 0 0は、 受信した画像データに基づいて 、 人、 車、 障害物、 標識又は路面上の文字等を認識する画像認識処理又は距 離検出処理を行ってもよい。 車外情報検出ユニッ ト 7 4 0 0は、 受信した画 像データに対して歪補正又は位置合わせ等の処理を行うとともに、 異なる撮 像部 7 4 1 0により撮像された画像データを合成して、 俯瞰画像又はパノラ マ画像を生成してもよい。 車外情報検出ユニッ ト 7 4 0 0は、 異なる撮像部 7 4 1 0により撮像された画像データを用いて、 視点変換処理を行ってもよ い。 [0254] In addition, the exterior information detection unit 740 performs image recognition processing or distance detection processing that recognizes people, vehicles, obstacles, signs, characters on the road surface, etc. based on the received image data. You can go. The exterior information detection unit 7400 performs processing such as distortion correction or position adjustment on the received image data, and combines the image data captured by different image capturing units 7410. An overhead image or a panoramic image may be generated. The vehicle exterior information detection unit 7400 may perform viewpoint conversion processing using image data captured by different image capturing units 7410.
[0255] 車内情報検出ユニッ ト 7 5 0 0は、 車内の情報を検出する。 車内情報検出 ユニッ ト 7 5 0 0には、 例えば、 運転者の状態を検出する運転者状態検出部 7 5 1 0が接続される。 運転者状態検出部 7 5 1 0は、 運転者を撮像する力 メラ、 運転者の生体情報を検出する生体センサ又は車室内の音声を集音する マイク等を含んでもよい。 生体センサは、 例えば、 座面又はステアリングホ イ—ル等に設けられ、 座席に座った搭乗者又はステアリングホイールを握る 運転者の生体情報を検出する。 車内情報検出ユニッ ト 7 5 0 0は、 運転者状 態検出部 7 5 1 0から入力される検出情報に基づいて、 運転者の疲労度合い 又は集中度合いを算出してもよいし、 運転者が居眠りをしていないかを判別 してもよい。 車内情報検出ユニッ ト 7 5 0 0は、 集音された音声信号に対し てノイズキャンセリング処理等の処理を行ってもよい。 [0255] The in-vehicle information detection unit 750 detects in-vehicle information. In-vehicle information detection The unit 7500 is connected to, for example, a driver state detection unit 7510 that detects the state of the driver. The driver state detection unit 7510 may include a camera for capturing an image of the driver, a biometric sensor for detecting biometric information of the driver, a microphone for collecting voice in the vehicle, and the like. The biometric sensor is provided on, for example, a seat surface or a steering wheel, and detects biometric information of a passenger sitting in a seat or a driver who holds a steering wheel. The in-vehicle information detection unit 750 may calculate the degree of fatigue or concentration of the driver based on the detection information input from the driver state detection unit 750. You may decide whether you are sleeping or not. The in-vehicle information detection unit 750 may perform processing such as noise canceling processing on the collected audio signal.
[0256] 統合制御ユニッ ト 7 6 0 0は、 各種プログラムにしたがって車両制御シス テム 7 0 0 0内の動作全般を制御する。 統合制御ユニッ ト 7 6 0 0には、 入 力部 7 8 0 0が接続されている。 入力部 7 8 0 0は、 例えば、 タッチパネル 、 ボタン、 マイクロフオン、 スイッチ又はレバー等、 搭乗者によって入力操 作され得る装置によって実現される。 統合制御ユニッ ト 7 6 0 0には、 マイ クロフオンにより入力される音声を音声認識することにより得たデータが入 力されてもよい。 入力部 7 8 0 0は、 例えば、 赤外線又はその他の電波を利 用したリモートコントロール装置であってもよいし、 車両制御システム 7 0 0 0の操作に対応した携帯電話又は P D A (Persona l D i g i ta l Ass i stant ) 等の外部接続機器であってもよい。 入力部 7 8 0 0は、 例えばカメラであ ってもよく、 その場合搭乗者はジェスチャにより情報を入力することができ る。 あるいは、 搭乗者が装着したウェアラブル装置の動きを検出することで 得られたデータが入力されてもよい。 さらに、 入力部 7 8 0 0は、 例えば、 上記の入力部 7 8 0 0を用いて搭乗者等により入力された情報に基づいて入 力信号を生成し、 統合制御ユニッ ト 7 6 0 0に出力する入力制御回路などを 含んでもよい。 搭乗者等は、 この入力部 7 8 0 0を操作することにより、 車 両制御システム 7 0 0 0に対して各種のデータを入力したり処理動作を指示 したりする。 [0257] 記憶部 7690は、 マイクロコンピュータにより実行される各種プログラ ムを記憶する ROM (Read Only Memory) 、 及び各種パラメータ、 演算結 果又はセンサ値等を記憶する R A M (Random Access Memory) を含んでい てもよい。 また、 記憶部 7690は、 H DD (Hard Disc Drive) 等の磁気 記憶デバイス、 半導体記憶デバイス、 光記憶デバイス又は光磁気記憶デバイ ス等によって実現してもよい。 [0256] The integrated control unit 760 controls overall operations in the vehicle control system 7000 according to various programs. An input unit 780 is connected to the integrated control unit 760. The input unit 780 is realized by a device such as a touch panel, a button, a microphone, a switch or a lever that can be operated by a passenger. The integrated control unit 760 may be input with data obtained by voice recognition of voice input by Microphone. The input unit 7800 may be, for example, a remote control device using infrared rays or other radio waves, or may be a mobile phone or a PDA (Personal lDigi) that supports the operation of the vehicle control system 7800. It may be an externally connected device such as ta l Assistant). The input unit 780 may be, for example, a camera, in which case the passenger can input information by gesture. Alternatively, the data obtained by detecting the movement of the wearable device worn by the passenger may be input. Further, the input unit 780 generates an input signal based on the information input by the passenger using the input unit 780 described above, and outputs the input signal to the integrated control unit 760. It may include an input control circuit for outputting. A passenger or the like operates the input unit 780 to input various data or instruct a processing operation to the vehicle control system 7000. [0257] The storage unit 7690 includes a ROM (Read Only Memory) for storing various programs executed by the microcomputer, and a RAM (Random Access Memory) for storing various parameters, calculation results, sensor values, and the like. You may stay. The storage unit 7690 may be realized by a magnetic storage device such as an HDD (Hard Disc Drive), a semiconductor storage device, an optical storage device, a magneto-optical storage device, or the like.
[0258] 汎用通信 I /F 7620は、 外部環境 7750に存在する様々な機器との 間の通信を仲介する汎用的な通信丨 /Fである。 汎用通信 I /F 7620は 、 G S M (登録商標) (Global System of Mobile communications) % W i MAX (登録商標) 、 LT E (登録商標) (Long Term Evolution) 若 しくは LT E— A (LTE-Advanced) などのセルラー通信プロトコル、 又は無 線 L A N (W i -F i (登録商標) ともいう) 、 B l u e t o o t h (登録 商標) などのその他の無線通信プロトコルを実装してよい。 汎用通信丨 /F 7620は、 例えば、 基地局又はアクセスポイントを介して、 外部ネッ トワ —ク (例えば、 インターネッ ト、 クラウドネッ トワーク又は事業者固有のネ ッ トワーク) 上に存在する機器 (例えば、 アプリケーシヨンサーバ又は制御 サーバ) へ接続してもよい。 また、 汎用通信丨 /F 7620は、 例えば P 2 P (Peer To Peer) 技術を用いて、 車両の近傍に存在する端末 (例えば、 運転者、 歩行者若しくは店舗の端末、 又は MTC (Machine Type Communic at ion) 端末) と接続してもよい。 [0258] The general-purpose communication I/F 7620 is a general-purpose communication I/F /F that mediates communication with various devices existing in the external environment 7750. General-purpose communication I/F 7620 is compatible with GSM (registered trademark) (Global System of Mobile communications) % W i MAX (registered trademark), LTE (registered trademark) (Long Term Evolution) or LT E— A (LTE- A cellular communication protocol such as Advanced) or a wireless LAN (also referred to as Wi-Fi (registered trademark)), or other wireless communication protocol such as Bluetooth (registered trademark) may be implemented. A general-purpose communication device/F 7620 is a device (for example, the device existing on the external network (for example, the Internet, the cloud network or the network unique to the operator)) via the base station or the access point (for example, Application server or control server). In addition, the general-purpose communication system /F 7620 uses, for example, P 2 P (Peer To Peer) technology to connect terminals (e.g., drivers, pedestrians or shops, or MTC (Machine Type Communic at ion) terminal).
[0259] 専用通信丨 /F 7630は、 車両における使用を目的として策定された通 信プロトコルをサボートする通信丨 /Fである。 専用通信 I /F 7630は 、 例えば、 下位レイヤの丨 E E E 802. 1 1 pと上位レイヤの丨 E E E 1 609との組合せである W A V E (Wi re less Access in Vehicle Enviro nment) 、 D S R C (Dedicated Short Range Communications) % 又はセ ルラー通信プロトコルといった標準プロトコルを実装してよい。 専用通信丨 /F 7630は、 典型的には、 車車間 (Vehicle to Vehicle) 通信、 路車 間 (Vehicle to Infrastructure) 通信、 車両と家との間 (Vehicle to H ome) の通信及び歩車間 (Vehicle to Pedestrian) 通信のうちの 1つ以上 を含む概念である V 2 X通信を遂行する。 [0259] The dedicated communication/F 7630 is a communication/F that supports a communication protocol designed for use in vehicles. The dedicated communication I/F 7630 is, for example, WAVE (Wi re less Access in Vehicle Environment), which is a combination of the lower layer EEE 802.1 p and the upper layer EEE 1 609, and the DSRC (Dedicated Short Range). Communications) % or cellular communication protocols may be implemented. Dedicated communication/F 7630 is typically used for vehicle-to-vehicle communication, vehicle-to-vehicle communication, and vehicle-to-house communication. V 2 X communication, which is a concept that includes one or more of ome) communication and Vehicle to Pedestrian communication.
[0260] 測位部 7640は、 例えば、 G N S S (Global Navigation Satellite System) 衛星からの G NS S信号 (例えば、 G PS (Global Positioning System) 衛星からの G PS信号) を受信して測位を実行し、 車両の緯度、 経 度及び高度を含む位置情報を生成する。 なお、 測位部 7640は、 無線アク セスポイントとの信号の交換により現在位置を特定してもよく、 又は測位機 能を有する携帯電話、 P H S若しくはスマートフォンといった端末から位置 情報を取得してもよい。 [0260] The positioning unit 7640 executes positioning, for example, by receiving a G NSS signal from a GNSS (Global Navigation Satellite System) satellite (for example, a G PS signal from a G PS (Global Positioning System) satellite), Generates location information including vehicle latitude, longitude and altitude. Note that the positioning unit 7640 may specify the current position by exchanging a signal with a wireless access point, or may acquire position information from a terminal having a positioning function, such as a mobile phone, PHS, or smartphone.
[0261] ビーコン受信部 7650は、 例えば、 道路上に設置された無線局等から発 信される電波あるいは電磁波を受信し、 現在位置、 渋滞、 通行止め又は所要 時間等の情報を取得する。 なお、 ビーコン受信部 7650の機能は、 上述し た専用通信丨 / F 7630に含まれてもよい。 [0261] The beacon receiving unit 7650 receives, for example, a radio wave or an electromagnetic wave transmitted from a wireless station or the like installed on a road, and acquires information such as the current position, traffic jam, traffic closure, or required time. The function of the beacon receiving unit 7650 may be included in the above-described dedicated communication/F 7630.
[0262] 車内機器丨 / F 7660は、 マイクロコンビユータ 76 1 0と車内に存在 する様々な車内機器 7760との間の接続を仲介する通信インタフェースで ある。 車内機器 I / F 7660は、 無線 L A N、 B l u e t o o t h (登録 商標) 、 N FC (Near Field Communication) 又は WUS B (Wireless U SB) といった無線通信プロトコルを用いて無線接続を確立してもよい。 また 、 車内機器丨 /F 7660は、 図示しない接続端子 (及び、 必要であればケ —ブル) を介して、 US B (Universal Serial Bus) 、 H D M I (登録商 標) (High-Definition Multimedia Interface、 又は MH L (Mobile Hig h-definition Link) 等の有線接続を確立してもよい。 車内機器 7760は 、 例えば、 搭乗者が有するモバイル機器若しくはウェアラブル機器、 又は車 両に搬入され若しくは取り付けられる情報機器のうちの少なくとも 1つを含 んでいてもよい。 また、 車内機器 7760は、 任意の目的地までの経路探索 を行うナビゲーシヨン装置を含んでいてもよい。 車内機器丨 /F 7660は 、 これらの車内機器 7760との間で、 制御信号又はデータ信号を交換する [0263] 車載ネッ トワーク 丨 / F 7 6 8 0は、 マイクロコンビュータ 7 6 1 0と通 信ネッ トワーク 7 0 1 0との間の通信を仲介するインタフエースである。 車 載ネッ トワーク 丨 / F 7 6 8 0は、 通信ネッ トワーク 7 0 1 0によりサボー 卜される所定のプロトコルに則して、 信号等を送受信する。 [0262] The in-vehicle device/F 7660 is a communication interface that mediates a connection between the micro computer 7610 and various in-vehicle devices 7760 existing in the vehicle. The in-vehicle device I/F 7660 may establish a wireless connection using a wireless communication protocol such as a wireless LAN, Bluetooth (registered trademark), NFC (Near Field Communication), or WUSB (Wireless U SB). In addition, the in-vehicle device /F 7660 can be connected to the USB (Universal Serial Bus), HDMI (registered trademark) (High-Definition Multimedia Interface, Alternatively, a wired connection such as MH L (Mobile Hi-definition Link) may be established.The in-vehicle device 7760 is, for example, a mobile device or a wearable device that the passenger has, or an information device that is carried in or attached to the vehicle. The in-vehicle device 7760 may include a navigation device for route search to any destination.The in-vehicle device/F 7660 may be a navigation device. Exchange control signals or data signals with in-vehicle equipment 7760 [0263] The in-vehicle network/F 760 is an interface that mediates communication between the micro computer 760 and the communication network 710. The on-board network/F 760 sends and receives signals, etc. according to a predetermined protocol supported by the communication network 710.
[0264] 統合制御ユニッ ト 7 6 0 0のマイクロコンビュータ 7 6 1 0は、 汎用通信 [0264] The integrated control unit 7600's micro-computer 7600 is for general-purpose communication.
I / F 7 6 2 0、 専用通信丨 / F 7 6 3 0、 測位部 7 6 4 0、 ビーコン受信 部 7 6 5 0、 車内機器丨 / F 7 6 6 0及び車載ネッ トワーク 丨 / F 7 6 8 0 のうちの少なくとも一つを介して取得される情報に基づき、 各種プログラム にしたがって、 車両制御システム 7 0 0 0を制御する。 例えば、 マイクロコ ンピュータ 7 6 1 0は、 取得される車内外の情報に基づいて、 駆動力発生装 置、 ステアリング機構又は制動装置の制御目標値を演算し、 駆動系制御ユニ ッ ト 7 1 0 0に対して制御指令を出力してもよい。 例えば、 マイクロコンビ ュータ 7 6 1 0は、 車両の衝突回避あるいは衝撃緩和、 車間距離に基づく追 従走行、 車速維持走行、 車両の衝突警告、 又は車両のレーン逸脱警告等を含 む A D A S (Advanced Dr i ver Ass i stance System) の機能実現を目的と した協調制御を行ってもよい。 また、 マイクロコンビュータ 7 6 1 0は、 取 得される車両の周囲の情報に基づいて駆動力発生装置、 ステアリング機構又 は制動装置等を制御することにより、 運転者の操作に拠らずに自律的に走行 する自動運転等を目的とした協調制御を行ってもよい。 I/F 760, Dedicated communication 丨 / F 763 0, Positioning unit 760, Beacon reception unit 765, In-vehicle equipment 丨 / F 760 and vehicle network 丨 / F 7 The vehicle control system 7000 is controlled according to various programs based on the information acquired through at least one of the 680. For example, the micro computer 760 calculates the control target value of the driving force generation device, the steering mechanism or the braking device based on the acquired information on the inside and outside of the vehicle, and the drive system control unit 710. A control command may be output for 0. For example, the micro computer 760 includes ADAS (Advanced Drone) that includes vehicle collision avoidance or impact mitigation, vehicle-based follow-up driving, vehicle speed maintenance driving, vehicle collision warning, and vehicle lane departure warning. i ver Ass i stance System) may be performed for cooperative control. In addition, the micro-computer 760 controls the driving force generator, steering mechanism, braking device, etc. based on the acquired information about the surroundings of the vehicle, so that it does not depend on the driver's operation. Coordinated control may be performed for the purpose of automatically driving the vehicle.
[0265] マイクロコンピュータ 7 6 1 0は、 汎用通信丨 / F 7 6 2 0、 専用通信 I / F 7 6 3 0、 測位部 7 6 4 0、 ビーコン受信部 7 6 5 0、 車内機器 I / F 7 6 6 0及び車載ネッ トワーク I / F 7 6 8 0のうちの少なくとも一つを介 して取得される情報に基づき、 車両と周辺の構造物や人物等の物体との間の 3次元距離情報を生成し、 車両の現在位置の周辺情報を含むローカル地図情 報を作成してもよい。 また、 マイクロコンビュータ 7 6 1 0は、 取得される 情報に基づき、 車両の衝突、 歩行者等の近接又は通行止めの道路への進入等 の危険を予測し、 警告用信号を生成してもよい。 警告用信号は、 例えば、 警 告音を発生させたり、 警告ランプを点灯させたりするための信号であってよ い。 [0265] Microcomputer 7 6 10 is for general-purpose communication / F 7 6 20, dedicated communication I / F 7 6 30, positioning unit 7 6 4 0, beacon receiving unit 7 6 5 0, in-vehicle device I / Based on the information acquired via at least one of the F 760 and in-vehicle network I / F 760, the 3D between the vehicle and the surrounding structures or objects such as people. The distance information may be generated and the local map information including the peripheral information of the current position of the vehicle may be generated. Further, the micro computer 760 may generate a warning signal by predicting a danger such as a vehicle collision, a proximity of a pedestrian or the like, or an approach to a closed road, based on the acquired information. The warning signal may be, for example, a signal for generating a warning sound or lighting a warning lamp. Yes.
[0266] 音声画像出力部 7 6 7 0は、 車両の搭乗者又は車外に対して、 視覚的又は 聴覚的に情報を通知することが可能な出力装置へ音声及び画像のうちの少な くとも一方の出力信号を送信する。 図 1 6の例では、 出力装置として、 オー ディオスピーカ 7 7 1 0、 表示部 7 7 2 0及びインストルメントパネル 7 7 3 0が例示されている。 表示部 7 7 2 0は、 例えば、 オンボードディスプレ イ及びへッ ドアップディスプレイの少なくとも一つを含んでいてもよい。 表 示部 7 7 2 0は、 A R (Augmented Rea l i ty) 表示機能を有していてもよい 。 出力装置は、 これらの装置以外の、 へッ ドホン、 搭乗者が装着する眼鏡型 ディスプレイ等のウェアラブルデバイス、 プロジェクタ又はランプ等の他の 装置であってもよい。 出力装置が表 装置の場合、 表 装置は、 マイクロコ ンピュータ 7 6 1 0が行った各種処理により得られた結果又は他の制御ユニ ッ トから受信された情報を、 テキスト、 イメージ、 表、 グラフ等、 様々な形 式で視覚的に表示する。 また、 出力装置が音声出力装置の場合、 音声出力装 置は、 再生された音声データ又は音響データ等からなるオーディオ信号をア ナログ信号に変換して聴覚的に出力する。 [0266] The audio/video output unit 760 provides at least one of audio and image to an output device capable of visually or audibly notifying information to a passenger of the vehicle or the outside of the vehicle. Send the output signal of. In the example of FIG. 16, an audio speaker 7710, a display unit 7720, and an instrument panel 7730 are illustrated as output devices. The display unit 7720 may include at least one of an onboard display and a head-up display, for example. The display unit 7720 may have an A R (Augmented Reality) display function. In addition to these devices, the output device may be a headphone, a wearable device such as a glasses-type display worn by a passenger, a projector, or another device such as a lamp. When the output device is a display device, the display device displays the results obtained by various processes performed by the microcomputer 7610 or the information received from another control unit as text, images, tables, and graphs. Visually display in various formats such as. When the output device is an audio output device, the audio output device converts an audio signal composed of reproduced audio data or acoustic data into an analog signal and outputs it audibly.
[0267] なお、 図 1 6に示した例において、 通信ネッ トワーク 7 0 1 0を介して接 続された少なくとも二つの制御ユニッ トが一つの制御ユニッ トとして一体化 されてもよい。 あるいは、 個々の制御ユニッ トが、 複数の制御ユニッ トによ り構成されてもよい。 さらに、 車両制御システム 7 0 0 0が、 図示されてい ない別の制御ユニッ トを備えてもよい。 また、 上記の説明において、 いずれ かの制御ユニッ トが担う機能の一部又は全部を、 他の制御ユニッ トに持たせ てもよい。 つまり、 通信ネッ トワーク 7 0 1 0を介して情報の送受信がされ るようになっていれば、 所定の演算処理が、 いずれかの制御ユニッ トで行わ れるようになってもよい。 同様に、 いずれかの制御ユニッ トに接続されてい るセンサ又は装置が、 他の制御ユニッ トに接続されるとともに、 複数の制御 ユニッ トが、 通信ネッ トワーク 7 0 1 0を介して相互に検出情報を送受信し てもよい。 \¥02020/174865 64 卩(:170?2019/050965 [0267] In the example shown in Fig. 16, at least two control units connected via the communication network 710 may be integrated as one control unit. Alternatively, each control unit may be composed of multiple control units. Further, the vehicle control system 700 may include another control unit (not shown). Further, in the above description, some or all of the functions of one of the control units may be given to another control unit. That is, as long as information is transmitted and received via the communication network 710, the predetermined arithmetic processing may be performed by any one of the control units. Similarly, a sensor or device that is connected to one of the control units is connected to another control unit, and multiple control units can detect each other over the communication network 710. You may send and receive information. \\02020/174865 64 卩(: 170?2019/050965
[0268] [本技術] [0268] [This technology]
本技術は、 以下の構成にすることもできる。 The present technology may also be configured as below.
[0269] < 1 > [0269] <1>
物体側より像側へ順に、 少なくとも一つのレンズ群で構成される第 1 レン ズユニッ トと、 第 1 自由曲面レンズと第 2自由曲面レンズで構成される第 2 レンズユニッ トと、 少なくとも一つのレンズ群で構成される第 3レンズユニ ッ トとにより構成され、 In order from the object side to the image side, a first lens unit including at least one lens group, a second lens unit including a first free-form surface lens and a second free-form surface lens, and at least one lens It consists of a third lens unit consisting of
前記第 1 レンズユニッ トと前記第 3レンズユニッ トは光軸に対して回転対 称な形状のレンズで構成されると共に同じ光軸上に配置され、 The first lens unit and the third lens unit are composed of lenses having a shape symmetrical with respect to the optical axis and are arranged on the same optical axis,
前記第 1 自由曲面レンズと前記第 2自由曲面レンズは同一形状にされ光軸 に対して 1 8 0度回転して配置され、 The first free-form surface lens and the second free-form surface lens have the same shape and are arranged by rotating 180 degrees with respect to the optical axis,
前記第 1 レンズユニッ トと前記第 3レンズユニッ トの光軸を 軸とし、 像 面上で 軸に垂直な軸を丫軸とし、 像面上で丫軸と 軸に垂直な軸を X軸と すると、 The optical axes of the first lens unit and the third lens unit are axes, the axis perpendicular to the axis on the image plane is the vertical axis, and the axis perpendicular to the axis on the image plane is the X axis. Then,
前記第 1 自由曲面レンズと前記第 2自由曲面レンズは丫軸方向へ移動可能 であり、 The first free-form surface lens and the second free-form surface lens are movable in the axial direction,
前記第 1 自由曲面レンズと前記第 2自由曲面レンズが互いに逆方向へ移動 することにより前記第 2レンズユニッ トの屈折力が可変であり、 By moving the first free-form surface lens and the second free-form surface lens in mutually opposite directions, the refracting power of the second lens unit is variable,
焦点距離が最も短い広角端状態から焦点距離が最も長い望遠端状態までレ ンズの位置状態が変化する際に、 前記第 1 レンズユニッ トと前記第 3レンズ ユニッ トを構成するレンズ群の一部が移動するのと合わせて、 前記第 1 自由 曲面レンズと前記第 2自由曲面レンズが丫軸方向へ移動する When the lens position changes from the wide-angle end state where the focal length is the shortest to the telephoto end state where the focal length is the longest, part of the lens groups that make up the first lens unit and the third lens unit. And the first free-form surface lens and the second free-form surface lens move in the axial direction.
可変焦点距離レンズ系。 Variable focal length lens system.
[0270] < 2 > [0270] <2>
下記の条件式 (1) を満足する Satisfies the following conditional expression (1)
前記 < 1 >に記載の可変焦点距離レンズ系。 The variable focal length lens system according to <1>.
( 1 ) 0 . 0 3 <八 2/å<0. 3 5 (1) 0 .0 3 <8 2/å <0.3 5
但し、 \¥02020/174865 65 卩(:170?2019/050965 However, \¥02020/174865 65 卩 (: 170?2019/050965
△ 2 : ø 27/¢ 2 △ 2: ø 27/¢ 2
¢ 27 :望遠端状態における第 2レンズュニッ トの屈折力 ¢ 27: Refracting power of the 2nd lens unit at the telephoto end
0 :広角端状態における第 2レンズュニッ トの屈折力 0: Refracting power of the second lens unit in the wide-angle end state
å : 干 1: /干 å: dried 1: / dried
干 1 :望遠端状態におけるレンズ系全体の焦点距離 D 1: Focal length of the entire lens system in the telephoto end state
干% :広角端状態におけるレンズ系全体の焦点距離 %: Focal length of the entire lens system in the wide-angle end state
とする。 And
[0271] <3> [0271] <3>
下記の条件式 (2) 及び条件式 (3) を満足する Satisfy the following conditional expressions (2) and (3)
前記 < 2 >に記載の可変焦点距離レンズ系。

但し、 However,
△ !_八 :広角端状態から望遠端状態までの第 1 自由曲面レンズの丫軸方向に おける移動量 △ !_ Eight: Amount of movement in the vertical axis direction of the first free-form surface lens from the wide-angle end state to the telephoto end state
△ !_巳 :広角端状態から望遠端状態までの第 2自由曲面レンズの丫軸方向に おける移動量 △ !_ _: The amount of movement of the second free-form surface lens in the vertical axis direction from the wide-angle end state to the telephoto end state.
干 1 :望遠端状態におけるレンズ系全体の焦点距離 D 1: Focal length of the entire lens system in the telephoto end state
とする。 And
[0272] <4> [0272] <4>
開口絞りが前記第 2レンズュニッ ト付近に配置され、 An aperture stop is arranged near the second lens unit,
下記の条件式 (4) を満足する Satisfy the following conditional expression (4)
前記 < 3 >に記載の可変焦点距離レンズ系。 The variable focal length lens system according to <3>.

但し、 However,
△ :開口絞りから第 2レンズュニッ トまでの 軸に沿った長さの最大値 干% :広角端状態におけるレンズ系全体の焦点距離 △: Maximum value along the axis from the aperture stop to the second lens unit%: Focal length of the entire lens system in the wide-angle end state
とする。 \¥02020/174865 66 卩(:170?2019/050965 And \¥02020/174865 66 卩(: 170?2019/050965
[0273] < 5 > [0273] <5>
下記の条件式 ( 5 ) を満足する Satisfy the following conditional expression (5)
前記 < 4 >に記載の可変焦点距離レンズ系。 The variable focal length lens system according to <4>.
( 5 ) 〇. 9 <丨 △!_八 丨 /丨 △!_巳 丨 < 1 . 1 (5) 0. 9 <丨△!_8丨 / 丨△!_ 跳丨 <1.1
但し、 However,
△ !_八 :広角端状態から望遠端状態までの第 1 自由曲面レンズの丫軸方向に おける移動量 △ !_ Eight: Amount of movement in the vertical axis direction of the first free-form surface lens from the wide-angle end state to the telephoto end state
△ !_巳 :広角端状態から望遠端状態までの第 2自由曲面レンズの丫軸方向に おける移動量 △ !_ _: The amount of movement of the second free-form surface lens in the vertical axis direction from the wide-angle end state to the telephoto end state.
とする。 And
[0274] < 6 > [0274] <6>
前記第 1 レンズユニッ トは、 物体側より像側へ順に、 正の屈折力を有する 第 1 レンズ群と負の屈折力を有する第 2レンズ群とを有し、 The first lens unit has, in order from the object side to the image side, a first lens group having a positive refractive power and a second lens group having a negative refractive power,
広角端状態から望遠端状態までレンズの位置状態が変化する際に、 前記第 1 レンズ群と前記第 2レンズ群との間隔が増大し、 前記第 2レンズ群と前記 第 2レンズユニッ トとの間隔が減少するように、 少なくとも第 2レンズ群が 光軸方向へ移動する When the position of the lens changes from the wide-angle end state to the telephoto end state, the distance between the first lens group and the second lens group increases, and the second lens unit and the second lens unit are separated from each other. At least the second lens group moves in the optical axis direction so that the distance decreases.
前記 < 5 >に記載の可変焦点距離レンズ系。 The variable focal length lens system according to <5>.
[0275] < 7 > [0275] <7>
前記第 3レンズユニッ トは被写体距離に応じて光軸方向へ移動するフォー カシングレンズを含む The third lens unit includes a focusing lens that moves in the optical axis direction according to the subject distance.
前記 < 6 >に記載の可変焦点距離レンズ系。 The variable focal length lens system according to <6>.
[0276] < 8 > [0276] <8>
可変焦点距離レンズ系と前記可変焦点距離レンズ系によって形成された光 学像を電気的信号に変換する撮像素子とを備え、 A variable focal length lens system and an image sensor for converting an optical image formed by the variable focal length lens system into an electrical signal,
前記可変焦点距離レンズ系は、 The variable focal length lens system,
物体側より像側へ順に、 少なくとも一つのレンズ群で構成される第 1 レン ズュニッ トと、 第 1 自由曲面レンズと第 2自由曲面レンズで構成される第 2 \¥02020/174865 67 卩(:170?2019/050965 From the object side to the image side, in order from the first side, the first lens unit is composed of at least one lens group, and the second lens unit is composed of the first and second free-form surface lenses. \¥02020/174865 67 卩(: 170?2019/050965
レンズユニッ トと、 少なくとも一つのレンズ群で構成される第 3レンズユニ ッ トとにより構成され、 A lens unit and a third lens unit composed of at least one lens group,
前記第 1 レンズユニッ トと前記第 3レンズユニッ トは光軸に対して回転対 称な形状のレンズで構成されると共に同じ光軸上に配置され、 The first lens unit and the third lens unit are composed of lenses having a shape symmetrical with respect to the optical axis and are arranged on the same optical axis,
前記第 1 自由曲面レンズと前記第 2自由曲面レンズは同一形状にされ光軸 に対して 1 8 0度回転して配置され、 The first free-form surface lens and the second free-form surface lens have the same shape and are arranged by rotating 180 degrees with respect to the optical axis,
前記第 1 レンズユニッ トと前記第 3レンズユニッ トの光軸を 軸とし、 像 面上で 軸に垂直な軸を丫軸とし、 像面上で丫軸と 軸に垂直な軸を X軸と すると、 The optical axes of the first lens unit and the third lens unit are axes, the axis perpendicular to the axis on the image plane is the vertical axis, and the axis perpendicular to the axis on the image plane is the X axis. Then,
前記第 1 自由曲面レンズと前記第 2自由曲面レンズは丫軸方向へ移動可能 であり、 The first free-form surface lens and the second free-form surface lens are movable in the axial direction,
前記第 1 自由曲面レンズと前記第 2自由曲面レンズが互いに逆方向へ移動 することにより前記第 2レンズユニッ トの屈折力が可変であり、 By moving the first free-form surface lens and the second free-form surface lens in mutually opposite directions, the refracting power of the second lens unit is variable,
焦点距離が最も短い広角端状態から焦点距離が最も長い望遠端状態までレ ンズの位置状態が変化する際に、 前記第 1 レンズユニッ トと前記第 3レンズ ユニッ トを構成するレンズ群の一部が移動するのと合わせて、 前記第 1 自由 曲面レンズと前記第 2自由曲面レンズが丫軸方向へ移動する When the lens position changes from the wide-angle end state where the focal length is the shortest to the telephoto end state where the focal length is the longest, part of the lens groups that make up the first lens unit and the third lens unit. And the first free-form surface lens and the second free-form surface lens move in the axial direction.
撮像装置。 Imaging device.
符号の説明 Explanation of symbols
[0277] 1 可変焦点距離レンズ系、 2 可変焦点距離レンズ系、 3 可変焦点距 離レンズ系、 II 1 第 1 レンズユニッ ト、 II 2 第 2レンズユニッ ト、 II 3 第 3レンズユニッ ト、 ◦ 1 第 1 レンズ群、 ◦ 2 第 2レンズ群、 0 3 第 3レンズ群、 0 4 第 4レンズ群、 0 5 第 5レンズ群、 0 6 第 6レン ズ群、 0 7 第 7レンズ群、 0 8 第 8レンズ群、 !_ 3 第 1 自由曲面レン ズ、 1_ 4 第 2自由曲面レンズ、 3 開口絞り、 1 0 0 撮像装置、 1 0 撮像素子 [0277] 1 variable focal length lens system, 2 variable focal length lens system, 3 variable focal length lens system, II 1 1st lens unit, II 2 2nd lens unit, II 3 3rd lens unit, ◦ 1 1st lens group, ◦ 2 2nd lens group, 0 3 3rd lens group, 0 4 4th lens group, 0 5 5th lens group, 0 6 6th lens group, 0 7 7th lens group, 0 8 8th lens group,! _ 3 1st free-form surface lens, 1_ 4 2nd free-form surface lens, 3 aperture stop, 100 imaging device, 10 imaging device
Claims


Priority Applications (4)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| US17/431,501 US12181647B2 (en) | 2019-02-27 | 2019-12-25 | Variable focal distance lens system and imaging device |
| CN201980092622.2A CN113474707A (en) | 2019-02-27 | 2019-12-25 | Variable focal length lens system and imaging apparatus |
| JP2021501645A JPWO2020174865A1 (en) | 2019-02-27 | 2019-12-25 | Variable focal length lens system and image pickup device |
| DE112019006933.0T DE112019006933T5 (en) | 2019-02-27 | 2019-12-25 | LENS SYSTEM WITH VARIABLE FOCAL LENGTH AND IMAGE RECORDING DEVICE |
Applications Claiming Priority (2)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| JP2019-034876 | 2019-02-27 | ||
| JP2019034876 | 2019-02-27 |
Publications (1)
| Publication Number | Publication Date |
|---|---|
| WO2020174865A1 true WO2020174865A1 (en) | 2020-09-03 |
Family
ID=72239478
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| PCT/JP2019/050965 Ceased WO2020174865A1 (en) | 2019-02-27 | 2019-12-25 | Variable-focal-length lens system and imaging device |
Country Status (5)
| Country | Link |
|---|---|
| US (1) | US12181647B2 (en) |
| JP (1) | JPWO2020174865A1 (en) |
| CN (1) | CN113474707A (en) |
| DE (1) | DE112019006933T5 (en) |
| WO (1) | WO2020174865A1 (en) |
Cited By (3)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN112068292A (en) * | 2020-09-08 | 2020-12-11 | 杭州梭钠科技有限公司 | Micro optical device and optical system provided with same |
| WO2022088086A1 (en) * | 2020-10-30 | 2022-05-05 | 欧菲光集团股份有限公司 | Optical imaging system, photographing module, and electronic device |
| CN115657408A (en) * | 2022-09-27 | 2023-01-31 | 中国科学院西安光学精密机械研究所 | Catadioptric two-gear zoom optical system |
Families Citing this family (3)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN114829988B (en) * | 2019-10-24 | 2024-05-07 | 索尼集团公司 | Lens system, method for controlling a lens system and computer program product |
| US11561391B2 (en) * | 2020-07-31 | 2023-01-24 | Immervision, Inc. | Optical system with dynamic distortion using freeform elements |
| CN114690388B (en) * | 2022-06-01 | 2022-10-21 | 江西联益光学有限公司 | Zoom lens |
Citations (5)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| US3305294A (en) * | 1964-12-03 | 1967-02-21 | Optical Res & Dev Corp | Two-element variable-power spherical lens |
| US3583790A (en) * | 1968-11-07 | 1971-06-08 | Polaroid Corp | Variable power, analytic function, optical component in the form of a pair of laterally adjustable plates having shaped surfaces, and optical systems including such components |
| JPS59116710A (en) * | 1982-12-24 | 1984-07-05 | Canon Inc | variable magnification optical system |
| JP2009505166A (en) * | 2005-08-22 | 2009-02-05 | イーストマン コダック カンパニー | Zoom lens system with variable power element |
| US20140204472A1 (en) * | 2011-06-28 | 2014-07-24 | The Technology Partnership Plc | Optical device |
Family Cites Families (6)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| US4836661A (en) | 1982-12-01 | 1989-06-06 | Canon Kabushiki Kaisha | Optical system of variable magnification power |
| JP3147167B2 (en) | 1990-06-11 | 2001-03-19 | オリンパス光学工業株式会社 | Zoom lens |
| JP4829547B2 (en) | 2005-06-27 | 2011-12-07 | キヤノン株式会社 | Zoom optical system |
| JP5929478B2 (en) * | 2011-06-17 | 2016-06-08 | セイコーエプソン株式会社 | Projection optical system and projector equipped with the same |
| JP2014534462A (en) * | 2011-10-07 | 2014-12-18 | シンガポール国立大学National University Of Singapore | MEMS type zoom lens system |
| DE102013112595B4 (en) * | 2013-11-15 | 2024-08-01 | Carl Zeiss Microscopy Gmbh | Arrangement for light sheet microscopy |
-
2019
- 2019-12-25 WO PCT/JP2019/050965 patent/WO2020174865A1/en not_active Ceased
- 2019-12-25 DE DE112019006933.0T patent/DE112019006933T5/en not_active Withdrawn
- 2019-12-25 JP JP2021501645A patent/JPWO2020174865A1/en active Pending
- 2019-12-25 US US17/431,501 patent/US12181647B2/en active Active
- 2019-12-25 CN CN201980092622.2A patent/CN113474707A/en not_active Withdrawn
Patent Citations (5)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| US3305294A (en) * | 1964-12-03 | 1967-02-21 | Optical Res & Dev Corp | Two-element variable-power spherical lens |
| US3583790A (en) * | 1968-11-07 | 1971-06-08 | Polaroid Corp | Variable power, analytic function, optical component in the form of a pair of laterally adjustable plates having shaped surfaces, and optical systems including such components |
| JPS59116710A (en) * | 1982-12-24 | 1984-07-05 | Canon Inc | variable magnification optical system |
| JP2009505166A (en) * | 2005-08-22 | 2009-02-05 | イーストマン コダック カンパニー | Zoom lens system with variable power element |
| US20140204472A1 (en) * | 2011-06-28 | 2014-07-24 | The Technology Partnership Plc | Optical device |
Cited By (3)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN112068292A (en) * | 2020-09-08 | 2020-12-11 | 杭州梭钠科技有限公司 | Micro optical device and optical system provided with same |
| WO2022088086A1 (en) * | 2020-10-30 | 2022-05-05 | 欧菲光集团股份有限公司 | Optical imaging system, photographing module, and electronic device |
| CN115657408A (en) * | 2022-09-27 | 2023-01-31 | 中国科学院西安光学精密机械研究所 | Catadioptric two-gear zoom optical system |
Also Published As
| Publication number | Publication date |
|---|---|
| US20220146799A1 (en) | 2022-05-12 |
| CN113474707A (en) | 2021-10-01 |
| US12181647B2 (en) | 2024-12-31 |
| DE112019006933T5 (en) | 2021-11-25 |
| JPWO2020174865A1 (en) | 2021-12-23 |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| JP7364022B2 (en) | Imaging lens and imaging device | |
| JP7428179B2 (en) | Optical system and imaging device | |
| JP7758127B2 (en) | Imaging lens and imaging device | |
| US12181647B2 (en) | Variable focal distance lens system and imaging device | |
| WO2020090368A1 (en) | Imaging lens and imaging device | |
| JP7711706B2 (en) | Fisheye lens and imaging device | |
| JP7661967B2 (en) | Zoom lens and imaging device | |
| JP2025065217A (en) | Zoom lens and imaging device | |
| JP7768137B2 (en) | Wide-angle lens and imaging device | |
| JP7661730B2 (en) | Imaging lens and imaging device | |
| JP7192852B2 (en) | Zoom lens and imaging device | |
| JP7740230B2 (en) | Zoom lens and imaging device | |
| JP7616212B2 (en) | Zoom lens and imaging device | |
| WO2024166548A1 (en) | Imaging optical system and imaging device | |
| JP7823455B2 (en) | Imaging lens and imaging device | |
| JP7735995B2 (en) | Zoom lens and imaging device | |
| WO2023153076A1 (en) | Zoom lens and imaging device | |
| WO2020174866A1 (en) | Variable-focal-length lens system and imaging device | |
| US20250155677A1 (en) | Zoom lens and imaging apparatus | |
| CN113906324B (en) | Optical system and camera device | |
| WO2024247472A1 (en) | Zoom lens and image capture device | |
| WO2024135126A1 (en) | Zoom lens and imaging device | |
| WO2025239028A1 (en) | Imaging optical system and imaging device | |
| WO2025253789A1 (en) | Zoom lens and imaging device |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| 121 | Ep: the epo has been informed by wipo that ep was designated in this application |
Ref document number: 19916629 Country of ref document: EP Kind code of ref document: A1 |
|
| ENP | Entry into the national phase |
Ref document number: 2021501645 Country of ref document: JP Kind code of ref document: A |
|
| 122 | Ep: pct application non-entry in european phase |
Ref document number: 19916629 Country of ref document: EP Kind code of ref document: A1 |