CN214856440U - Cleaning robot with direction handle capable of automatically resetting - Google Patents
Cleaning robot with direction handle capable of automatically resetting Download PDFInfo
- Publication number
- CN214856440U CN214856440U CN202120838296.XU CN202120838296U CN214856440U CN 214856440 U CN214856440 U CN 214856440U CN 202120838296 U CN202120838296 U CN 202120838296U CN 214856440 U CN214856440 U CN 214856440U
- Authority
- CN
- China
- Prior art keywords
- fixed mounting
- handlebar
- axletree
- automobile body
- mounting
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Active
Links
- 238000004140 cleaning Methods 0.000 title claims abstract description 50
- 238000006073 displacement reaction Methods 0.000 claims description 21
- 230000002146 bilateral effect Effects 0.000 claims description 6
- 230000008878 coupling Effects 0.000 claims description 5
- 238000010168 coupling process Methods 0.000 claims description 5
- 238000005859 coupling reaction Methods 0.000 claims description 5
- 230000005540 biological transmission Effects 0.000 claims description 3
- 238000009434 installation Methods 0.000 claims 1
- 229910003460 diamond Inorganic materials 0.000 description 3
- 239000010432 diamond Substances 0.000 description 3
- 230000005611 electricity Effects 0.000 description 3
- 230000000694 effects Effects 0.000 description 2
- 230000010354 integration Effects 0.000 description 2
- 230000036632 reaction speed Effects 0.000 description 2
- 230000001105 regulatory effect Effects 0.000 description 2
- 230000009286 beneficial effect Effects 0.000 description 1
- 238000006243 chemical reaction Methods 0.000 description 1
- 230000007547 defect Effects 0.000 description 1
- 230000002349 favourable effect Effects 0.000 description 1
- 230000001360 synchronised effect Effects 0.000 description 1
- 239000002699 waste material Substances 0.000 description 1
Images


Landscapes
- Electric Vacuum Cleaner (AREA)
Abstract
The utility model discloses a direction handle can automatic re-setting's cleaning machines people, which comprises a carriage body, automobile body lower extreme fixed mounting has cleaning device, the anterior fixed mounting in automobile body upper end has the fixed plate, the fixed plate upper end is provided with the axletree, inside the axletree extends to the automobile body, axletree upper end fixed mounting has the car to stand, the car stands left end and the equal fixed mounting of right-hand member has the handlebar, the left side handlebar left end fixed mounting has left hand handlebar, right side handlebar right-hand member fixed mounting has the speed governing handlebar, speed governing handlebar and automobile body electric connection, automobile body upper end rear portion fixed mounting has the electrical distribution box, electrical distribution box upper end fixed mounting has the touch-sensitive screen, electrical distribution box upper end fixed mounting has the handle, the handle is located the touch-sensitive screen rear. A cleaning machines people that direction handle can automatic re-setting, through setting up the automatic re-setting that axletree, sleeve, torsional spring and spacing post realized the handlebar, be convenient for carry on autopilot and manual driving switch.
Description
Technical Field
The utility model relates to a cleaning machines people technical field, in particular to direction handle cleaning machines people that can automatic re-setting.
Background
At present, the majority of the domestic existing automatic driving cleaning robots only rely on automatic driving to work, the cleaning robots are complex to operate and long in waiting time when needing manual operation temporarily, the cleaning vehicle body and the electrical distribution box are difficult to push, the waiting time is long, the problem of labor operation is solved, and the cleaning robots cannot be completely utilized to work. The existing cleaning robot has the following disadvantages: 1. most of the existing cleaning robots are not provided with the function of automatically resetting the handle bars, so that the cleaning robots have the defects of low reaction speed, labor waste, complex cleaning operation and the like during automatic work; 2. the automatic driving and manual driving switching operation of the existing cleaning robot is complex, and the application prospect of the cleaning robot cannot be met.
SUMMERY OF THE UTILITY MODEL
The utility model discloses a main aim at provides a direction handle can automatic re-setting's cleaning machines people, can effectively solve the problem among the background art.
In order to achieve the above purpose, the utility model adopts the following technical scheme:
the utility model provides a direction handle cleaning machines people that can automatic re-setting, includes the automobile body, automobile body lower extreme fixed mounting has cleaning device, the anterior fixed mounting in automobile body upper end has the fixed plate, the fixed plate upper end is provided with the axletree, the axletree extends to inside the automobile body, axletree upper end fixed mounting has the car to stand, the car stands the equal fixed mounting of left end and right-hand member has the handlebar, the left side handlebar left end fixed mounting has left hand handlebar, right side handlebar right-hand member fixed mounting has the speed governing handlebar, speed governing handlebar and automobile body electric connection, automobile body upper end rear portion fixed mounting has the electricity distribution box, electricity distribution box upper end fixed mounting has the touch-sensitive screen, electricity distribution box upper end fixed mounting has the handle, the handle is located the touch-sensitive screen rear.
Preferably, fixed plate lower extreme fixed mounting has two support columns, two the support column is bilateral symmetry and distributes, two the common fixed mounting of support column lower extreme has the mounting panel, mounting panel upper end swing joint has the sleeve, sleeve and axletree fixed connection, mounting panel upper end fixed mounting has two spacing posts, two spacing post uses the sleeve to be bilateral symmetry and distributes as the center, the torsional spring has been cup jointed in the sleeve, the torsional spring cup joints at the axletree surface.
Preferably, the axle lower extreme runs through the mounting panel and fixed mounting has the rhombus bearing, rhombus bearing lower extreme fixed mounting has the shaft coupling, shaft coupling lower extreme fixed mounting has the angle displacement sensor.
Preferably, the front part of the lower end of the mounting plate is fixedly provided with an L-shaped support, the right end of the L-shaped support is fixedly provided with a U-shaped mounting plate, the upper wall of the inner cavity of the U-shaped mounting plate is fixedly connected with the upper end of an angular displacement sensor, the lower wall of the inner cavity of the U-shaped mounting plate is fixedly provided with a manual driving circuit board, and the lower part of the front end of the U-shaped mounting plate is fixedly provided with an angular displacement mounting pipe.
Preferably, the manual driving circuit board is electrically connected with the angular displacement sensor, the vehicle body and the speed regulation handlebar.
Preferably, the axle is in transmission connection with the vehicle body.
Compared with the prior art, the utility model discloses following beneficial effect has:
1. the utility model relates to a cleaning robot that direction handle can automatic re-setting realizes the automatic re-setting of handlebar through setting up axletree, sleeve, torsional spring and spacing post, during manual driving, rotate the handlebar and drive the sleeve along with rotatory, the torsional spring also rotates together, rotate to a certain position, when the torsional spring is touched the spacing post of opposite side by the spacing post of one side, maximum rotation angle has been reached this moment, and because the characteristic of torsional spring, there is a pulling force of going back, so under the effect of torsional spring force after loosening hand, the handlebar wholly gets back to the initial position, effectively improve cleaning robot's reaction rate, and make things convenient for operating personnel to operate this cleaning robot;
2. the utility model relates to a direction handle can automatic re-setting's cleaning machines people is through setting up the manual driving circuit board, cleaning machines people's autopilot and manual driving automatic switch-over are realized to speed governing handlebar and automobile body, when needs switch to manual driving, switching button on the operating personnel accessible speed governing handlebar can switch over the driving mode, the manual driving circuit board is the core of manual driving module, the manual driving circuit board is the PCB circuit board, it sends cleaning machines people's driving motor after the data integration of speed governing handlebar and angle displacement sensor on, it is as an organic whole with manual driving module and cleaning machines people, data synchronization, be convenient for operate.
Drawings
Fig. 1 is a top view of the overall structure of a cleaning robot with a direction handle capable of automatically resetting according to the present invention;
FIG. 2 is a rear view of the overall structure of the cleaning robot with the direction handle capable of automatically resetting according to the present invention;
fig. 3 is a schematic view of a connection structure of an axle of a cleaning robot with a direction handle capable of automatically resetting according to the present invention;
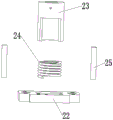
fig. 4 is an exploded view of the connection structure of the torsion spring of the cleaning robot with the direction handle capable of automatically resetting.
In the figure: 1. a vehicle body; 2. a cleaning device; 3. a fixing plate; 4. an axle; 5. turning and standing; 6. a handlebar; 7. a left-hand handlebar; 8. a speed-regulating handlebar; 9. an electrical distribution box; 10. a touch screen; 11. a handle; 21. a support pillar; 22. mounting a plate; 23. a sleeve; 24. a torsion spring; 25. a limiting column; 26. a U-shaped mounting plate; 27. a diamond bearing; 28. a coupling; 29. an angular displacement sensor; 30. an angular displacement mounting tube; 31. an L-shaped bracket; 32. the circuit board is driven manually.
Detailed Description
In order to make the technical means, creation features, achievement purposes and functions of the present invention easy to understand, the present invention is further described below with reference to the following embodiments.
In the description of the present invention, it should be noted that the terms "upper", "lower", "inner", "outer", "front end", "rear end", "both ends", "one end", "the other end" and the like indicate orientations or positional relationships based on the orientations or positional relationships shown in the drawings, and are only for convenience of description and simplification of description, but do not indicate or imply that the device or element to which the reference is made must have a specific orientation, be constructed in a specific orientation, and be operated, and thus, should not be construed as limiting the present invention. Furthermore, the terms "first" and "second" are used for descriptive purposes only and are not to be construed as indicating or implying relative importance.
In the description of the present invention, it is to be noted that, unless otherwise explicitly specified or limited, the terms "mounted," "disposed," "connected," and the like are to be construed broadly, and for example, "connected" may be either fixedly connected or detachably connected, or integrally connected; can be mechanically or electrically connected; they may be connected directly or indirectly through intervening media, or they may be interconnected between two elements. The specific meaning of the above terms in the present invention can be understood in specific cases to those skilled in the art.
As shown in fig. 1-4, a cleaning robot with a direction handle capable of automatically resetting comprises a vehicle body 1, a cleaning device 2 is fixedly mounted at the lower end of the vehicle body 1, a fixing plate 3 is fixedly mounted at the front part of the upper end of the vehicle body 1, an axle 4 is arranged at the upper end of the fixing plate 3, the axle 4 extends into the vehicle body 1, a vehicle stand 5 is fixedly mounted at the upper end of the axle 4, a handle 6 is fixedly mounted at the left end and the right end of the vehicle stand 5, a left handlebar 7 is fixedly mounted at the left end of the left handlebar 6, a speed regulation handlebar 8 is fixedly mounted at the right end of the right handlebar 6, the speed regulation handlebar 8 is electrically connected with the vehicle body 1, an electrical distribution box 9 is fixedly mounted at the rear part of the upper end of the vehicle body 1, a touch screen 10 is fixedly mounted at the upper end of the electrical distribution box 9, a handle 11 is fixedly mounted at the upper end of the electrical distribution box 9, and the handle 11 is located behind the touch screen 10.
3 lower extreme fixed mounting of fixed plate has two support columns 21, two support columns 21 are bilateral symmetry and distribute, the common fixed mounting of two support column 21 lower extremes has mounting panel 22, mounting panel 22 upper end swing joint has sleeve 23, sleeve 23 and 4 fixed connection of axletree, mounting panel 22 upper end fixed mounting has two spacing posts 25, two spacing posts 25 use sleeve 23 to be bilateral symmetry and distribute as the center, cup jointed torsional spring 24 in the sleeve 23, torsional spring 24 cup joints at 4 surfaces of axletree, torsional spring 24 installs in sleeve 23, sleeve 23 passes through the screw and screws up with axletree 4.
The lower end of the axle 4 penetrates through the mounting plate 22 and is fixedly provided with a diamond bearing 27, the lower end of the diamond bearing 27 is fixedly provided with a coupler 28, the lower end of the coupler 28 is fixedly provided with an angular displacement sensor 29, the angular displacement sensor 29 and the axle 4 are integrally concentric, a rotating column of the angular displacement sensor 29 extends into the coupler 28 and is tightly connected with the coupler 28, namely, the rotation of the handlebar 6 can also drive the rotating column of the angular displacement sensor 29 to rotate, so that the automobile body rotates left and right according to the operation.
The front part of the lower end of the mounting plate 22 is fixedly provided with an L-shaped support 31, the right end of the L-shaped support 31 is fixedly provided with a U-shaped mounting plate 26, the upper wall of the inner cavity of the U-shaped mounting plate 26 is fixedly connected with the upper end of an angular displacement sensor 29, the lower wall of the inner cavity of the U-shaped mounting plate 26 is fixedly provided with an artificial driving circuit board 32, the lower part of the front end of the U-shaped mounting plate 26 is fixedly provided with an angular displacement mounting pipe 30, the angular displacement mounting pipe 30 and the U-shaped mounting plate 26 are of an integrated structure, the artificial driving circuit board 32 is the prior art, the artificial driving circuit board 32 is a PCB circuit board, the data of the speed regulating handlebar 8 and the angular displacement sensor 29 are integrated and then sent to a driving motor of the cleaning robot, the artificial driving module and the cleaning robot are integrated, the data are synchronous, and the operation is convenient.
The manual driving circuit board 32 is electrically connected with the angular displacement sensor 29, the vehicle body 1 and the speed regulation handlebar 8, the speed regulation handlebar 8 is a three-gear reversing speed regulation handlebar with low speed, medium speed and high speed, and can move forward and backward, and the movement mode of the vehicle can be changed by adjusting a switching button on the handlebar 8.
The axle 4 is in transmission connection with the vehicle body 1, and the axle 4 rotates to drive the vehicle body 1 to steer.
It should be noted that, the utility model relates to a cleaning robot with direction handle capable of automatic reset, through setting up the axletree 4, the sleeve 23, the torsional spring 24 and the spacing post 25 realize the automatic reset of the handlebar 6, during manual driving, the rotating handlebar 11 drives the sleeve 23 to rotate along with it, the torsional spring 24 also rotates together, rotate to a certain position, when the torsional spring 24 touches the spacing post 25 of the other side by the spacing post 25 of one side, the maximum rotation angle has been reached at this moment, and because of the characteristic of the torsional spring 24, there is a backward pulling force, so under the effect of torsional spring 24 power after loosening hand, the handlebar 6 returns to the initial position as a whole, effectively improve the reaction speed of the cleaning robot, and facilitate the operator to operate the cleaning robot, through setting up the manual driving circuit board 32, the automatic driving and the automatic switching of manual driving of the cleaning robot are realized by the speed regulating handlebar 8 and the automobile body 1, when needs switch to manual drive, the driving mode can be switched to the switching button on the operating personnel accessible speed governing handlebar 8, and manual drive circuit board 32 is the core of manual driving module, and manual driving circuit board 32 is the PCB circuit board, and it sends cleaning machines people's driving motor after speed governing handlebar 8 and angular displacement sensor 29's data integration on, closes manual driving module and cleaning machines people as an organic whole, and data synchronization is convenient for operate, the utility model discloses simple structure, the practicality is strong, is favorable to cleaning machines people's using widely.
The basic principles and the main features of the invention and the advantages of the invention have been shown and described above. It will be understood by those skilled in the art that the present invention is not limited to the above embodiments, and that the foregoing embodiments and descriptions are provided only to illustrate the principles of the present invention without departing from the spirit and scope of the present invention. The scope of the invention is defined by the appended claims and equivalents thereof.
Claims (6)
1. The utility model provides a direction handle can automatic re-setting's cleaning machines people, includes automobile body (1), its characterized in that: the automobile body (1) lower extreme fixed mounting has cleaning device (2), the anterior fixed mounting in automobile body (1) upper end has fixed plate (3), fixed plate (3) upper end is provided with axletree (4), axletree (4) extend to automobile body (1) inside, axletree (4) upper end fixed mounting has the car to found (5), the car is found (5) the equal fixed mounting of left end and right-hand member and is had handlebar (6), the left side handlebar (6) left end fixed mounting has left hand handlebar (7), the right side handlebar (6) right-hand member fixed mounting has speed governing handlebar (8), speed governing handlebar (8) and automobile body (1) electric connection, automobile body (1) upper end rear portion fixed mounting has electrical distribution box (9), electrical distribution box (9) upper end fixed mounting has touch-sensitive screen (10), electrical distribution box (9) upper end fixed mounting has handle (11), the handle (11) is located behind the touch screen (10).
2. A cleaning robot having a directional handle capable of automatically returning according to claim 1, wherein: fixed plate (3) lower extreme fixed mounting has two support columns (21), two support column (21) are bilateral symmetry and distribute, two the common fixed mounting of support column (21) lower extreme has mounting panel (22), mounting panel (22) upper end swing joint has sleeve (23), sleeve (23) and axletree (4) fixed connection, mounting panel (22) upper end fixed mounting has two spacing post (25), two spacing post (25) use sleeve (23) to be bilateral symmetry and distribute as the center, cup jointed torsional spring (24) in sleeve (23), torsional spring (24) cup joint at axletree (4) surface.
3. A cleaning robot having a directional handle capable of automatically returning according to claim 1, wherein: axletree (4) lower extreme runs through mounting panel (22) and fixed mounting has diamond-shaped bearing (27), diamond-shaped bearing (27) lower extreme fixed mounting has shaft coupling (28), shaft coupling (28) lower extreme fixed mounting has angle displacement sensor (29).
4. A cleaning robot having a directional handle capable of automatically returning according to claim 2, wherein: the utility model discloses a manual driving's circuit board, including mounting panel (22), mounting panel (22) lower extreme front portion fixed mounting has L shape support (31), L shape support (31) right-hand member fixed mounting has U-shaped mounting panel (26), U-shaped mounting panel (26) inner chamber upper wall and angular displacement sensor (29) upper end fixed connection, U-shaped mounting panel (26) inner chamber lower wall fixed mounting has manual driving circuit board (32), U-shaped mounting panel (26) front end lower part fixed mounting has angular displacement installation pipe (30).
5. A cleaning robot with a direction handle capable of automatically resetting as claimed in claim 4, wherein: and the manual driving circuit board (32) is electrically connected with the angular displacement sensor (29), the vehicle body (1) and the speed regulation handlebar (8).
6. A cleaning robot having a directional handle capable of automatically returning according to claim 1, wherein: the axle (4) is in transmission connection with the vehicle body (1).
Priority Applications (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| CN202120838296.XU CN214856440U (en) | 2021-04-23 | 2021-04-23 | Cleaning robot with direction handle capable of automatically resetting |
Applications Claiming Priority (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| CN202120838296.XU CN214856440U (en) | 2021-04-23 | 2021-04-23 | Cleaning robot with direction handle capable of automatically resetting |
Publications (1)
| Publication Number | Publication Date |
|---|---|
| CN214856440U true CN214856440U (en) | 2021-11-26 |
Family
ID=78948466
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| CN202120838296.XU Active CN214856440U (en) | 2021-04-23 | 2021-04-23 | Cleaning robot with direction handle capable of automatically resetting |
Country Status (1)
| Country | Link |
|---|---|
| CN (1) | CN214856440U (en) |
Cited By (1)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN115336935A (en) * | 2022-08-29 | 2022-11-15 | 坎德拉(深圳)科技创新有限公司 | Cleaning robot |
-
2021
- 2021-04-23 CN CN202120838296.XU patent/CN214856440U/en active Active
Cited By (1)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN115336935A (en) * | 2022-08-29 | 2022-11-15 | 坎德拉(深圳)科技创新有限公司 | Cleaning robot |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| CN219523947U (en) | Multifunctional outdoor folding trailer | |
| CN113954757A (en) | Central control screen multi-motion mode integrated mechanism | |
| CN108839765A (en) | A kind of robot for cleaning the water surface | |
| CN214832278U (en) | Novel steam cleaning robot | |
| CN218889601U (en) | Cleaning robot control device and cleaning robot | |
| CN201554995U (en) | TV bracket capable of being controlled remotely from various aspects | |
| CN102795290A (en) | Steering device for lightweight vehicle | |
| CN210542120U (en) | Electric wheelchair and detachable power wheel | |
| EP1069489A3 (en) | Vehicular input device capable of being adjusted its mounting posture to vehicle in conformity with physical constitution and form of operator | |
| CN206324933U (en) | An intelligent electric wheelchair capable of automatic charging | |
| CN213687108U (en) | A humidification device for constant temperature and humidity laboratory equipment | |
| CN213053429U (en) | Miniature welding robot | |
| CN109137685B (en) | A remote-controlled cement trowel walking device | |
| CN220599228U (en) | Municipal works prefabricated component auxiliary stay board with altitude mixture control | |
| CN221418392U (en) | Steering assembly and floor washing robot | |
| CN219298806U (en) | Trowelling machine control mechanism with booster unit and driving trowelling machine | |
| CN222874714U (en) | PVC transparent tube processingequipment | |
| CN221991405U (en) | Visual computer lab figure image output device | |
| CN217074506U (en) | EPS steering mechanism for ground washing vehicle | |
| CN214057216U (en) | Electromagnet universal driving wheel | |
| CN216886504U (en) | Integrated controller of electric automobile | |
| CN213277007U (en) | A robotic education kit | |
| CN220685931U (en) | Snow shoveling device | |
| CN219893349U (en) | Building intercom convenient to dismouting is maintained | |
| CN220421592U (en) | A kind of reduction motor |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| GR01 | Patent grant | ||
| GR01 | Patent grant |