EP0171633A1 - Outil pour examiner la surface interne d'un gros tube - Google Patents
Outil pour examiner la surface interne d'un gros tube Download PDFInfo
- Publication number
- EP0171633A1 EP0171633A1 EP85108916A EP85108916A EP0171633A1 EP 0171633 A1 EP0171633 A1 EP 0171633A1 EP 85108916 A EP85108916 A EP 85108916A EP 85108916 A EP85108916 A EP 85108916A EP 0171633 A1 EP0171633 A1 EP 0171633A1
- Authority
- EP
- European Patent Office
- Prior art keywords
- pipe
- tool
- actuating
- strut
- axle
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Withdrawn
Links
- 238000007689 inspection Methods 0.000 claims abstract description 22
- 239000000523 sample Substances 0.000 abstract description 6
- 230000009977 dual effect Effects 0.000 description 1
Images

Classifications
-
- G—PHYSICS
- G21—NUCLEAR PHYSICS; NUCLEAR ENGINEERING
- G21C—NUCLEAR REACTORS
- G21C17/00—Monitoring; Testing ; Maintaining
- G21C17/017—Inspection or maintenance of pipe-lines or tubes in nuclear installations
-
- Y—GENERAL TAGGING OF NEW TECHNOLOGICAL DEVELOPMENTS; GENERAL TAGGING OF CROSS-SECTIONAL TECHNOLOGIES SPANNING OVER SEVERAL SECTIONS OF THE IPC; TECHNICAL SUBJECTS COVERED BY FORMER USPC CROSS-REFERENCE ART COLLECTIONS [XRACs] AND DIGESTS
- Y02—TECHNOLOGIES OR APPLICATIONS FOR MITIGATION OR ADAPTATION AGAINST CLIMATE CHANGE
- Y02E—REDUCTION OF GREENHOUSE GAS [GHG] EMISSIONS, RELATED TO ENERGY GENERATION, TRANSMISSION OR DISTRIBUTION
- Y02E30/00—Energy generation of nuclear origin
- Y02E30/30—Nuclear fission reactors
Definitions
- This invention relates to remotely controlled tools for use in relatively inaccessible areas, and more particularly to a tool for internally inspecting elbows in large pipes.
- the centering section is secured to the inner surface of the pipe and the scanning section is extended to urge the inspection sleds against the pipe wall.
- the present invention provides a tool for inspecting the curved, or elbow portion of a large pipe by uniquely coordinating of the centering and supporting function, with the inspection probe translation function.
- the inspection struts can be rotated to enable gimballed sleds to maintain perpendicularity with respect their respective traversed surfaces, while the centering section provides a firm, centered base.
- Several scan rotations can be taken from a given base position, since the scanning and centering sections are independent during the inspection mode.
- the precise location of the sleds can be controlled and recorded based only on the known coordinates of the positioner, without significant uncertainties added by the inspection tool itself.
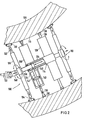
- the basic operation of the tool 100 involves a scanning section 112 interacting with a centering section 114.
- the centering section 114 centers and supports the inspection tool 100, while the extension mechanism 116 and rotator mechanism 118 on the remote positioner 102 control the scanning section 112.
- Energizing the actuator or centering cylinders 120 secures the tool against the inner surface of the pipe 106. Either longitudinal or rotational motion may be imparted to the scanning section 112, even at the pipe elbow 110 through the flexibility provided by the dual universal joint 122.
- the scanning section 112 carries pivoted or gimballed sleds 126 which follow the pipe contour.
- the scanning section 112 includes a hub or axle member 128 coaxially disposed within the slide cylinder 124 and adapted to rotate and slide therewithin.
- a set of strut members 130 extend diametrically from the axle member 128, at preferably both ends thereof, outside the actuating cylinders 120.
- Inspection probe sleds 126 are located on outer strut segments 132 which are preferably outwardly biased by controlled air pressure through the axle member 128 and strut 130.
- the sleds 126 are preferably gimbal led 134 to allow the sleds to maintain perpendicularity with respect to the pipe inner wall 110.
- Each actuating cylinder 120 preferably includes an outer actuator portion 136 having support pads 138 thereon for engaging the pipe walls to prevent sliding.
- the outer actuator portion 136 is preferably controlled by a piston 140 to which is also connected an inner rod 142 that passes through an opening 144 in the slide cylinder or sleeve 124.
- Locking pads 146 are adapted to engage the axle member 128 when the piston 140 moves towards the sleeve 124, thereby retracting the outer portion 136 while locking the scanning section 112 to the centering section 114. This locks the longitudinal position of the strut member 130 relative to the actuating member 120 and enables the extension mechanism 116 on the remote positioner ( Figure 1) to push the entire inspection tool 100 to a new basic location deeper into the pipe 106.
- a mounting boss 148 is located on the end of the axle member closest to the positioner 102, for connecting the tool 100 to the means for imparting longitudinal and rotational movement to the axle member 128, or scanning section 112.
- the scanning section may be considered the primary component that is connected to and controlled by the positioner 102 .
- the centering section 114 is relatively slidable and selectively lockable thereto, for providing centering and support during the movement of the scanning section associated with the surface inspection operation.
Landscapes
- Physics & Mathematics (AREA)
- Engineering & Computer Science (AREA)
- Plasma & Fusion (AREA)
- General Engineering & Computer Science (AREA)
- High Energy & Nuclear Physics (AREA)
- Monitoring And Testing Of Nuclear Reactors (AREA)
- Investigating Or Analyzing Materials By The Use Of Ultrasonic Waves (AREA)
Applications Claiming Priority (2)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| US635853 | 1984-07-30 | ||
| US06/635,853 US4581938A (en) | 1984-07-30 | 1984-07-30 | Tool for scanning the inner surface of a large pipe |
Publications (1)
| Publication Number | Publication Date |
|---|---|
| EP0171633A1 true EP0171633A1 (fr) | 1986-02-19 |
Family
ID=24549387
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| EP85108916A Withdrawn EP0171633A1 (fr) | 1984-07-30 | 1985-07-16 | Outil pour examiner la surface interne d'un gros tube |
Country Status (2)
| Country | Link |
|---|---|
| US (1) | US4581938A (fr) |
| EP (1) | EP0171633A1 (fr) |
Cited By (10)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| WO1994018679A1 (fr) * | 1993-02-01 | 1994-08-18 | Siemens Aktiengesellschaft | Element de transport pouvant avancer automatiquement a l'interieur d'un tuyau |
| WO1997002452A1 (fr) * | 1995-07-04 | 1997-01-23 | Force-Instituttet | Robot mobile d'inspection interieure de conduites |
| EP2136374A1 (fr) * | 2008-06-17 | 2009-12-23 | GE-Hitachi Nuclear Energy Americas LLC | Outillage destiné à l'inspection et/ou au traitement à distance de la surface interne de tuyauteries ou de récipients de forme allongée, en particulier dans le circuit de refroidissement d'un réacteur nucléaire, et procédé d'utilisation d'un tel outillage |
| US10427290B2 (en) | 2017-07-18 | 2019-10-01 | General Electric Company | Crawler robot for in situ gap inspection |
| US10427734B2 (en) | 2017-07-18 | 2019-10-01 | General Electric Company | Omnidirectional traction module for a robot |
| US10434641B2 (en) | 2017-07-18 | 2019-10-08 | General Electric Company | In situ gap inspection robot system and method |
| US10596713B2 (en) | 2017-07-18 | 2020-03-24 | General Electric Company | Actuated sensor module and method for in situ gap inspection robots |
| US10603802B2 (en) | 2017-07-18 | 2020-03-31 | General Electric Company | End region inspection module and method for in situ gap inspection robot system |
| US12038119B2 (en) | 2019-08-20 | 2024-07-16 | Ge Infrastructure Technology Llc | Sensor interface module with scissor lift for plurality of sensors, and visual inspection module with dual view paths for robot |
| US12151751B2 (en) | 2019-08-20 | 2024-11-26 | Ge Infrastructure Technology Llc | Traction module for robot with variable extension positions |
Families Citing this family (36)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| US4685966A (en) * | 1985-07-29 | 1987-08-11 | Mcdonnell Douglas Corporation | Surface tracking apparatus |
| US4760876A (en) * | 1986-09-02 | 1988-08-02 | Westinghouse Electric Corp. | Remote inspection device transport system |
| US4757716A (en) * | 1986-06-26 | 1988-07-19 | Westinghouse Electric Corp. | Boresonic inspection system |
| IN169006B (fr) * | 1986-06-26 | 1991-08-10 | Westinghouse Electric Corp | |
| FI890183L (fi) * | 1988-01-15 | 1989-07-16 | Shawn E Egger | Anordning foer roerelse i en roerformad ledning. |
| US5121694A (en) * | 1991-04-02 | 1992-06-16 | Zollinger William T | Pipe crawler with extendable legs |
| US5285689A (en) * | 1991-07-16 | 1994-02-15 | The United States Of America As Represented By The United States Department Of Energy | Piping inspection instrument carriage with precise and repeatable position control and location determination |
| US5265129A (en) * | 1992-04-08 | 1993-11-23 | R. Brooks Associates, Inc. | Support plate inspection device |
| US5305356B1 (en) * | 1992-05-14 | 1998-09-01 | Brooks Support Systems Inc | Inspection device |
| US5371363A (en) * | 1993-07-26 | 1994-12-06 | Lilimpakis; Emmanuel | Device for measuring radiation within a pipe |
| US5453688A (en) * | 1993-08-23 | 1995-09-26 | Atomic Energy Of Canada Limited | Rotating probe for inspecting tubes having an eccentric housing for supporting sensing means |
| US5370006A (en) * | 1993-09-20 | 1994-12-06 | The United States Of America As Represented By The United States Department Of Energy | Piping inspection carriage having axially displaceable sensor |
| US5375530A (en) * | 1993-09-20 | 1994-12-27 | The United States Of America As Represented By The Department Of Energy | Pipe crawler with stabilizing midsection |
| US5574223A (en) * | 1994-04-05 | 1996-11-12 | Gas Research Institute | Scan assembly and method using scan rate modulation |
| GB2301187B (en) * | 1995-05-22 | 1999-04-21 | British Gas Plc | Method of and apparatus for locating an anomaly in a duct |
| US5756908A (en) * | 1996-07-15 | 1998-05-26 | Framatome Technologies, Inc. | Probe positioner |
| GB9617115D0 (en) | 1996-08-15 | 1996-09-25 | Astec Dev Ltd | Pipeline traction system |
| US6722442B2 (en) | 1996-08-15 | 2004-04-20 | Weatherford/Lamb, Inc. | Subsurface apparatus |
| US5760306A (en) * | 1996-08-30 | 1998-06-02 | Framatome Technologies, Inc. | Probe head orientation indicator |
| US6215836B1 (en) * | 1998-05-07 | 2001-04-10 | Electric Power Research Institute, Inc. | Apparatus and method for ultrasonically examining remotely located welds in cast stainless steel nuclear steam supply systems |
| GB0028619D0 (en) * | 2000-11-24 | 2001-01-10 | Weatherford Lamb | Traction apparatus |
| GB0206246D0 (en) * | 2002-03-15 | 2002-05-01 | Weatherford Lamb | Tractors for movement along a pipepline within a fluid flow |
| GB2401130B (en) * | 2003-04-30 | 2006-11-01 | Weatherford Lamb | A traction apparatus |
| US7337673B2 (en) * | 2005-07-11 | 2008-03-04 | The Boeing Company | Ultrasonic array probe apparatus, system, and method for traveling over holes and off edges of a structure |
| US7512207B2 (en) * | 2005-04-12 | 2009-03-31 | General Electric Company | Apparatus for delivering a tool into a submerged bore |
| US7543512B2 (en) * | 2005-04-13 | 2009-06-09 | General Electric Company | Bore inspection probe |
| US7201055B1 (en) * | 2005-10-10 | 2007-04-10 | General Electric Company | Ultrasonic miniature air gap inspection crawler |
| JP4773459B2 (ja) * | 2005-12-16 | 2011-09-14 | ビ−エイイ− システムズ パブリック リミテッド カンパニ− | 溶接構造体の欠陥検出 |
| US20080087112A1 (en) * | 2006-01-04 | 2008-04-17 | General Electric Company | Senior Ultrasonic Miniature Air Gap Inspection Crawler |
| US7681452B2 (en) * | 2006-01-04 | 2010-03-23 | General Electric Company | Junior ultrasonic miniature air gap inspection crawler |
| US7555966B2 (en) * | 2006-05-30 | 2009-07-07 | General Electric Company | Micro miniature air gap inspection crawler |
| US7839282B1 (en) * | 2006-12-27 | 2010-11-23 | The United States Of America As Represented By The United States Department Of Energy | Capacitance probe for detection of anomalies in non-metallic plastic pipe |
| WO2009094627A1 (fr) * | 2008-01-25 | 2009-07-30 | Veracity Technology Solutions, Llc | Procédé et appareil pour examiner des disques de turbine à gaz |
| US20150233787A1 (en) * | 2014-02-19 | 2015-08-20 | Abb Technology Ag | Air gap crawler installation device |
| CN105806941B (zh) * | 2014-12-30 | 2018-08-21 | 中核武汉核电运行技术股份有限公司 | 一种真空吸盘式小管径管道内壁水浸超声检查装置 |
| CN105806955B (zh) * | 2014-12-30 | 2018-09-28 | 中核武汉核电运行技术股份有限公司 | 一种小径管内壁检查超声探头夹持结构 |
Citations (4)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| FR2336681A1 (fr) * | 1975-12-22 | 1977-07-22 | Kraftwerk Union Ag | Support de systemes pour l'examen ultrasonique de joints de tubulure, joints de raccordement tubulaire et aretes de tubulure dans des reservoirs sous pression, notamment des cuves de reacteur de centrale nucleaire |
| DE2640055A1 (de) * | 1976-09-06 | 1978-03-09 | Kraftwerk Union Ag | Rohrkruemmermanipulator, insbesondere zur ultraschallpruefung bei kernreaktoranlagen |
| EP0061078A2 (fr) * | 1981-03-25 | 1982-09-29 | Kraftwerk Union Aktiengesellschaft | Manipulateur mobile pour le transport contrôlé à distance d'appareils de contrôle et d'instruments le long des voies d'avancement à l'intérieur de tubes, de préférence pour installations nucléaires |
| EP0105418A1 (fr) * | 1982-10-06 | 1984-04-18 | Rainer Hitzel | Manipulateur pour tubes destiné à pénétrer dans des conduites |
Family Cites Families (3)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| DE2154015C3 (de) * | 1971-10-29 | 1974-05-09 | Maschinenfabrik Augsburg-Nuernberg Ag, 8900 Augsburg | Einrichtung zum Durchführen von Untersuchungen und Wiederholungsprüfungen an den Innenflächen von oben offenen Druckbehältern |
| US4218923A (en) * | 1979-02-07 | 1980-08-26 | Triad & Associates, Inc. | System for monitoring the condition of a pipeline |
| US4432271A (en) * | 1981-08-17 | 1984-02-21 | Combustion Engineering, Inc. | Locomotion unit for a tool support adapted for progression through passageways |
-
1984
- 1984-07-30 US US06/635,853 patent/US4581938A/en not_active Expired - Fee Related
-
1985
- 1985-07-16 EP EP85108916A patent/EP0171633A1/fr not_active Withdrawn
Patent Citations (4)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| FR2336681A1 (fr) * | 1975-12-22 | 1977-07-22 | Kraftwerk Union Ag | Support de systemes pour l'examen ultrasonique de joints de tubulure, joints de raccordement tubulaire et aretes de tubulure dans des reservoirs sous pression, notamment des cuves de reacteur de centrale nucleaire |
| DE2640055A1 (de) * | 1976-09-06 | 1978-03-09 | Kraftwerk Union Ag | Rohrkruemmermanipulator, insbesondere zur ultraschallpruefung bei kernreaktoranlagen |
| EP0061078A2 (fr) * | 1981-03-25 | 1982-09-29 | Kraftwerk Union Aktiengesellschaft | Manipulateur mobile pour le transport contrôlé à distance d'appareils de contrôle et d'instruments le long des voies d'avancement à l'intérieur de tubes, de préférence pour installations nucléaires |
| EP0105418A1 (fr) * | 1982-10-06 | 1984-04-18 | Rainer Hitzel | Manipulateur pour tubes destiné à pénétrer dans des conduites |
Cited By (10)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| WO1994018679A1 (fr) * | 1993-02-01 | 1994-08-18 | Siemens Aktiengesellschaft | Element de transport pouvant avancer automatiquement a l'interieur d'un tuyau |
| WO1997002452A1 (fr) * | 1995-07-04 | 1997-01-23 | Force-Instituttet | Robot mobile d'inspection interieure de conduites |
| EP2136374A1 (fr) * | 2008-06-17 | 2009-12-23 | GE-Hitachi Nuclear Energy Americas LLC | Outillage destiné à l'inspection et/ou au traitement à distance de la surface interne de tuyauteries ou de récipients de forme allongée, en particulier dans le circuit de refroidissement d'un réacteur nucléaire, et procédé d'utilisation d'un tel outillage |
| US10427290B2 (en) | 2017-07-18 | 2019-10-01 | General Electric Company | Crawler robot for in situ gap inspection |
| US10427734B2 (en) | 2017-07-18 | 2019-10-01 | General Electric Company | Omnidirectional traction module for a robot |
| US10434641B2 (en) | 2017-07-18 | 2019-10-08 | General Electric Company | In situ gap inspection robot system and method |
| US10596713B2 (en) | 2017-07-18 | 2020-03-24 | General Electric Company | Actuated sensor module and method for in situ gap inspection robots |
| US10603802B2 (en) | 2017-07-18 | 2020-03-31 | General Electric Company | End region inspection module and method for in situ gap inspection robot system |
| US12038119B2 (en) | 2019-08-20 | 2024-07-16 | Ge Infrastructure Technology Llc | Sensor interface module with scissor lift for plurality of sensors, and visual inspection module with dual view paths for robot |
| US12151751B2 (en) | 2019-08-20 | 2024-11-26 | Ge Infrastructure Technology Llc | Traction module for robot with variable extension positions |
Also Published As
| Publication number | Publication date |
|---|---|
| US4581938A (en) | 1986-04-15 |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| US4581938A (en) | Tool for scanning the inner surface of a large pipe | |
| US3809607A (en) | Reactor vessel in-service inspection assembly | |
| US4406856A (en) | Removal of portions of tubes from steam generator of nuclear reactor | |
| US4196049A (en) | Segmented articulating manipulator arm for nuclear reactor vessel inspection apparatus | |
| US5189933A (en) | Clamshell mounted pipe nozzle weld milling machine with centering apparatus | |
| US4757716A (en) | Boresonic inspection system | |
| US4307514A (en) | Bore diameter measurement gage | |
| US5028381A (en) | Device for the ultrasonic non-destructive testing of a circular weld inside a steam generator tube | |
| JPS6057543B2 (ja) | 管湾曲部検査用操作装置 | |
| WO2002044709A9 (fr) | Systeme d'essai ultrasonore | |
| KR20090131263A (ko) | 원자로 냉각재 시스템 또는 다른 처리 응용에 사용되는 용접부, 파이프, 용기 및/또는 다른 구성요소를 원격으로 검사 및/또는 처리하는 방법 및 장치 | |
| EP0251698A2 (fr) | Système d'inspection d'alésages par ultrasons | |
| US4505323A (en) | Apparatus for inspecting heat exchanger tubes | |
| GB2540075A (en) | Improvements relating to pipe measurement | |
| US4149932A (en) | Emergency disconnect means for the manipulator arm of a nuclear reactor vessel inspection apparatus | |
| US20020080905A1 (en) | Remote automated nuclear reactor jet pump diffuser inspection tool | |
| EP1900906A2 (fr) | Procédé et dispositifs pour l'inspection par robot des composants de la chambre de combustion d'une turbine | |
| CN120028439A (zh) | 一种大型法兰锻件缺陷检测装置及检测方法 | |
| EP0652069B1 (fr) | Appareil et procédé pour positionner sélectivement des modules d'outil pour une opération de soudage d'un tube | |
| CN110683019A (zh) | 一种船舶的侧推装置安装工艺 | |
| CN110702714A (zh) | 异型节管射线探伤升降结构及异型节管射线探伤机 | |
| US2567548A (en) | Well tubing calipering and recording device | |
| CN101458228B (zh) | 蒸汽发生器传热管涡流检测探头定位标定方法 | |
| US4165254A (en) | Pulley system including emergency locking means for nuclear reactor vessel inspection apparatus | |
| JPH06148378A (ja) | 取付ボルトの超音波探傷検査装置 |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| PUAI | Public reference made under article 153(3) epc to a published international application that has entered the european phase |
Free format text: ORIGINAL CODE: 0009012 |
|
| AK | Designated contracting states |
Designated state(s): BE DE FR NL SE |
|
| 17P | Request for examination filed |
Effective date: 19860307 |
|
| 17Q | First examination report despatched |
Effective date: 19870126 |
|
| STAA | Information on the status of an ep patent application or granted ep patent |
Free format text: STATUS: THE APPLICATION IS DEEMED TO BE WITHDRAWN |
|
| 18D | Application deemed to be withdrawn |
Effective date: 19890202 |
|
| RIN1 | Information on inventor provided before grant (corrected) |
Inventor name: WENTZELL, TIMOTHY H. |