EP0870461A1 - Système d'entrainement pour le déplacement d'un robot ou d'un véhicule sur des surfaces planes, inclinées ou voûtées, en particulier sur des constructions vitrées - Google Patents
Système d'entrainement pour le déplacement d'un robot ou d'un véhicule sur des surfaces planes, inclinées ou voûtées, en particulier sur des constructions vitrées Download PDFInfo
- Publication number
- EP0870461A1 EP0870461A1 EP98250120A EP98250120A EP0870461A1 EP 0870461 A1 EP0870461 A1 EP 0870461A1 EP 98250120 A EP98250120 A EP 98250120A EP 98250120 A EP98250120 A EP 98250120A EP 0870461 A1 EP0870461 A1 EP 0870461A1
- Authority
- EP
- European Patent Office
- Prior art keywords
- robot
- cable
- drum
- support frame
- control
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Withdrawn
Links
Images

Classifications
-
- A—HUMAN NECESSITIES
- A47—FURNITURE; DOMESTIC ARTICLES OR APPLIANCES; COFFEE MILLS; SPICE MILLS; SUCTION CLEANERS IN GENERAL
- A47L—DOMESTIC WASHING OR CLEANING; SUCTION CLEANERS IN GENERAL
- A47L1/00—Cleaning windows
- A47L1/02—Power-driven machines or devices
Definitions
- the invention relates to a drive device for Moving a robot or vehicle on flat, inclined or curved surfaces, especially one Glass construction, as well as a robot with drive device.
- Glass surfaces have a major problem in choosing one suitable kinematics for the drive and the Direction control of the robot or vehicle. If the construction of the glass surface has elements, that can serve as guiding elements for the robot and which allow force input, e.g. B. rail systems, become these elements for getting around used. Are such constructive elements not available or unsuitable, the force must be applied done directly into the glass.
- the invention is therefore based on the object Drive device for moving a robot or Vehicle on the surfaces in particular a glass structure to create a smooth forward movement without excessive point loads, which can cause the glass to break, ensures and a correction of the movement in the transverse direction.
- the device according to the invention Drive wheel with a high coefficient of friction in the Direction of the wheel in the direction of travel and non-driven Wheels with a very low coefficient of friction has, with all wheels on a support frame are attached, on the one hand, a clean forward movement the component of a robot or of a vehicle supporting frame without spinning or slip and on the other hand a slight side Pushing or turning allows.
- the lateral deviation and the facilities Rotation of the support frame determined and corresponding Corrections made with a control device the correction devices depending on the Size of the lateral deviation and the twist controls.
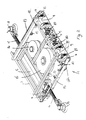
- Figures 1 and 2 show perspective views of a cleaning robot, the device according to the invention having.
- a robot 1 which in Embodiment designed as a cleaning robot and that on a glass roof or a glass envelope moves a hall and the glass surface cleans according to its width.
- a Grid construction suitable which a predetermined grid Dimension forms ..
- the glass panes are thereby on glass mounts under the grid construction appropriate.
- the cleaning robot essentially has one square support frame 2 on which the necessary Components are attached.
- free-running wheels 4 attached to all four corners, the preferably consist of a Teflon material or have a Teflon coating. It can also be a other material is chosen, it is important that it a material with a very low coefficient of friction is, which makes the robot 1 slide and easily can rotate.
- the hitneren part of the Frame 2 in the middle for example, of an electric motor driven drive wheel 3 provided that the support frame 2 in particular on horizontal glass surfaces emotional.
- This drive wheel 3 is one pneumatic cylinder 5 can be lifted off the glass surface or lowerable.
- the drive wheel 3 consists of a Material that has a high coefficient of friction.
- the robot in the present embodiment is designed as a cleaning robot, is in the direction of travel seen at the front on the support frame perpendicular to Moving direction attached a roller brush 6, the extends over the entire width of the support frame 2.
- the sides of the support frame are elongated Arms 7 arranged on which via swivel head assemblies 17 plate brushes 8 are attached.
- the arms 7 are retractable and extendable and are designed by an electric motor 18 driven by toothed belts.
- a cable drum is on or on the support frame 2 16 with drive motor and a hose drum 15 attached with drive motor.
- the cable drum 16 takes one or more electrical lines, the at least for the power supply of the serve the supporting frame 2 mounted electrical parts, as a cable while the hose drum 15 picks up a water hose. Cable and water hose are handled when moving the robot 1.
- the hose end of the on the hose reel 15 provided hose is with a not shown Water distribution system provided that over Water jets in the area of the roller brush 6 and the plate brushes 8 splashes.
- rope drums 9 At the rear end of the support frame 2 are two rope drums 9 arranged as far as possible after are offset outside.
- Ropes On the rope drums 9 are Ropes, not shown, wound up normally as safety ropes to prevent the robot from falling serve and in the process of the robot from the rope drums 9 are unwound. With curved or inclined glass surfaces, they are also used for Pulling up the robot 1.
- the rope drums 9 are drum drives 10 each having electric motors assigned with corresponding gear transmissions.
- the ropes are each across the width of the rope drums and are recorded with a given cable tension wound up or unwound.
- the drum drives and the measuring devices designed as cable pull sensors 11 are for each rope drum 9 to a control loop interconnected, over which the given cable tension can be met.
- the control and regulating device is trained as a microcomputer or as a PC and also serves to control the drive of the drive wheel 3 and the motors 18 for retracting and extending the linear arms 7 and the swivel heads 17.
- the robot 1 also has two measuring wheels 12, near the rope drums 9, ideally directly above the entry point of the rope on the drum (However, this cannot be realized because the entry point over the width of the rope drum 9 changes).
- the measuring wheels 12 are likewise with the control device, not shown connected and are connected to the cable drum drives 10 and the electric drive of the drive wheel 3 trained as control loops. Via the measuring wheels 12 is, for example, by counting the revolutions of the Measuring wheels 12 determines the distance traveled.
- sensors such as distance sensors, be provided, the construction elements detect what makes another statement be met via the routes covered can, because the construction elements in predetermined Grids or dimensions are arranged. Depending on The signals of these sensors can the measuring wheels 12th be readjusted.
- the support frame 2 is with lateral slide rails 13 provided, each with a pneumatic piston-cylinder arrangement 14 are retractable and retractable and those for support on external construction parts to serve.
- the compressed air for the pneumatic components is about a not shown, on Support frame 2 attached compressor won.
- the robot 1 is a service vehicle that is not is shown assigned to the top vertex a hall is arranged and with electric drives and distance measuring devices is provided over which he is moved in the direction of the hall axis.
- the ropes of the cable drums 11 of the robot 1 are with the service vehicle connected just like the cable of the Cable drum and the hose of the hose drum.
- the power supply is on the service vehicle provided that over the cable the cable drum 9 supplies the robot 1 with the necessary voltage, and it can also be called a microcomputer or PC trained control device provided be.
- the service vehicle shows at least one automatic pick-up device, of which the assigned robot 1 on the glass surface discontinued or taken up by the glass surface.
- the robot 1 From the service vehicle at the apex of the glass roof discontinued, and the driven wheel is lowered. It works against the rope drums 9 itself unwinding ropes, whereby over the control loops, through which the measured values of the draw wire sensors are processed are regulated to the specified cable tension becomes. This is done via appropriate signals, the control device to the drum drives 10 delivers.
- the Slide rails 13 extended until they each to the Construction elements in the grid of the grid construction bump, causing the robot 1 between aligns with the grid since the non-driven ones Wheels due to the low coefficient of friction no resistance to a uniform shift represent. However, in this case there is alignment the drive wheel 3 raised. After aligning the piston-cylinder arrangements become depressurized made, and the beginning of the Procedure with the drive wheel 3 lowered is carried out.
- the lateral displacement is done via the slide rails 13 found. If the robot moves sideways off the desired direction of travel, he bumps into the existing construction elements, and, since the Piston-cylinder assemblies 14 have been depressurized, the respective piston is slowly retracted.
- a proximity sensor is located in or on the piston-cylinder arrangement provided a signal to the control device releases when the piston approaches. This signal triggers the necessary correction of the side Deviation from.
- control device sends a signal to the pneumatic drive for the drive wheel 3, whereby the latter is lifted off the glass surface.
- the lateral shift is by extending again the side slide rails 13 performed.
- the correction of the rotation is also lifted Driving wheel performed when the robot 1 is located on an inclined glass surface.
- the control device regulates the cable drums 9 invalid, whose associated measuring wheel 12 the lesser Amount or the smaller measurement result.
- For the control loop of the other rope drum 9 gives the Control device a high setpoint for the cable tension before, causing the drive 10 of this rope drum 9 is pressed until it turns of the entire robot 1 around the entry point of the stationary rope due to the "winding" of the other rope, both measured values of the measuring wheels 12 match. This corrects the twisting, and that Drive wheel can be lowered again.
- the correction can also be done by regulating the Cable tension is carried out via both control loops will.
- the movement is stabilized of the robot 1 in that the front, not driven wheels 4 perpendicular to the wheel axis by one small angle, in the exemplary embodiment z. B. 15 °, are rotatably mounted, the vertical axis, in Seen driving direction, arranged in front of the wheel axle is. A deflection caused by external disturbances the wheels from the direction of travel lead to a restoring moment, that the wheels 4 in the original Direction pulls.
- the robot 1 is retracted when the robot is raised Drive wheel 3 only using the control loops the cable drums 9 and the measuring wheels 12 performed.
- the former front wheels 4 in the middle position with a locked pneumatic cylinder, not shown and therefore also have one for this direction of travel stabilizing effect.
- the cleaning is carried out during the downward movement of the respective robot 1 on the glass surface by means of Roller brushes 6 and the side of the robot 1 by means of the plate brushes 8 performed. Between the glass suspensions the robot 1 cleans over this width with the roller brush 6. To the glass suspensions, the due to the external grid shell of the hall construction are required to be able to drive around the side arms 7 retracted and extended. The plate brushes 8 are pivoted over the swivel heads 17, which also in the hidden area behind the glass hangers can be cleaned. While the process of the robot will be the side Arms depending on the selected travel speed of the robot constantly moving in and out, to clean the entire side glass surface. However, the drive 10 of the cable drums 9 and / or the drive wheel 3 also controlled or be regulated that the robot 1 each time extending the arm 7 stops, advances and retracts stops again.
- the brushes 6,8 are placed over the hose of the Hose reel 15 supplied water.
- the roller brush 6 faces the center of the roller brush bristles that get longer because of their own weight of the robot 1 the glass panes easily bend, and there can be an even contact pressure the bristles on the glass are guaranteed.
- the explained device for moving a robot can also be used with other robots, such as an inspection robot or generally a processing robot, be used.
- the latter can, for example Work such as painting, sandblasting, grinding, etc. perform on facades.
- Work such as painting, sandblasting, grinding, etc. perform on facades.
- cable drum and hose drum with Corresponding cables and hoses are provided, whereby any fluid or also in the hoses Colors for painting or the like can flow.
Landscapes
- Manipulator (AREA)
Applications Claiming Priority (4)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| DE19716740 | 1997-04-11 | ||
| DE19716741 | 1997-04-11 | ||
| DE1997116741 DE19716741C2 (de) | 1997-04-11 | 1997-04-11 | Vorrichtung zum Reinigen der Flächen einer Glaskonstruktion |
| DE1997116740 DE19716740C1 (de) | 1997-04-11 | 1997-04-11 | Vorrichtung zum Bewegen eines Roboters oder Fahrzeugs auf der Fläche einer Glaskonstruktion |
Publications (1)
| Publication Number | Publication Date |
|---|---|
| EP0870461A1 true EP0870461A1 (fr) | 1998-10-14 |
Family
ID=26035958
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| EP98250120A Withdrawn EP0870461A1 (fr) | 1997-04-11 | 1998-04-03 | Système d'entrainement pour le déplacement d'un robot ou d'un véhicule sur des surfaces planes, inclinées ou voûtées, en particulier sur des constructions vitrées |
Country Status (2)
| Country | Link |
|---|---|
| US (1) | US5959424A (fr) |
| EP (1) | EP0870461A1 (fr) |
Cited By (10)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| CN102228374A (zh) * | 2011-06-14 | 2011-11-02 | 南昌大学 | 用于壁面清洁机器人的清洁单元 |
| EP2386364A1 (fr) * | 2010-04-23 | 2011-11-16 | Anton Jäger | Dispositif de nettoyage pour panneaux solaire |
| CN103084346A (zh) * | 2011-10-28 | 2013-05-08 | 上海久能能源科技发展有限公司 | 一种屋面用太阳能光伏清洗机 |
| CN104224036A (zh) * | 2014-08-29 | 2014-12-24 | 平湖普英特高层设备有限公司 | 擦窗机c型轨电机爬轨器 |
| CN106073654A (zh) * | 2016-07-27 | 2016-11-09 | 山东英才学院 | 高层建筑幕墙自动清洗机 |
| CN108324197A (zh) * | 2017-12-29 | 2018-07-27 | 陈玉玲 | 一种高层楼寓外墙擦洗喷涂机器人 |
| CN108724165A (zh) * | 2018-06-21 | 2018-11-02 | 宁波介量机器人技术有限公司 | 一种绳缆约束机器人 |
| CN109674391A (zh) * | 2018-12-28 | 2019-04-26 | 上海石猴智能科技有限公司 | 一种擦玻璃机器人障碍物检测装置及检测方法 |
| CN111035335A (zh) * | 2019-12-18 | 2020-04-21 | 南京驭逡通信科技有限公司 | 一种便于清洁死角的清洁机器人 |
| CN112025734A (zh) * | 2020-09-08 | 2020-12-04 | 湖南汉坤实业有限公司 | 一种清洁机器人 |
Families Citing this family (42)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| US6965165B2 (en) | 1998-12-21 | 2005-11-15 | Mou-Shiung Lin | Top layers of metal for high performance IC's |
| IL141300A0 (en) | 2001-02-07 | 2002-03-10 | Kandelshein Menachem | A method and apparatus for flat surface treatment |
| WO2003022532A2 (fr) | 2001-09-09 | 2003-03-20 | Advanced Robotic Vehicles, Inc. | Robot portant un outil adherant aux surfaces |
| CN100496368C (zh) * | 2002-09-24 | 2009-06-10 | 三宅彻 | 擦窗装置 |
| US20060048800A1 (en) * | 2004-09-09 | 2006-03-09 | Rast Rodger H | Automated building exterior cleaning apparatus |
| ATE523130T1 (de) | 2005-02-18 | 2011-09-15 | Irobot Corp | Selbstfahrender flächenreinigungsroboter für nass-und trockenreinigung |
| JP2008060532A (ja) * | 2006-08-04 | 2008-03-13 | Seiko Epson Corp | 半導体装置 |
| CN101695437B (zh) * | 2009-10-01 | 2011-09-21 | 博宇(无锡)科技有限公司 | 单卷筒多绳缠绕机构 |
| US8640558B2 (en) * | 2011-09-12 | 2014-02-04 | Honeywell International Inc. | System for the automated inspection of structures at height |
| EP2625995A1 (fr) | 2012-02-13 | 2013-08-14 | E.M.M.P. S.r.l. | Dispositif pour le nettoyage des surfaces et similaire |
| EP3104194B1 (fr) | 2012-08-27 | 2019-02-06 | Aktiebolaget Electrolux | Système de positionnement de robot |
| US9483055B2 (en) | 2012-12-28 | 2016-11-01 | Irobot Corporation | Autonomous coverage robot |
| US9282867B2 (en) | 2012-12-28 | 2016-03-15 | Irobot Corporation | Autonomous coverage robot |
| CN104034318B (zh) * | 2013-03-08 | 2018-01-05 | 科沃斯机器人股份有限公司 | 铅垂校验装置及其具有该铅垂校验装置的擦玻璃机器人 |
| CN110448222A (zh) | 2013-04-15 | 2019-11-15 | 伊莱克斯公司 | 机器人真空吸尘器 |
| CN105101855A (zh) | 2013-04-15 | 2015-11-25 | 伊莱克斯公司 | 具有伸出的侧刷的机器人真空吸尘器 |
| CN104510410A (zh) * | 2013-09-27 | 2015-04-15 | 张晨 | 一种高空擦玻璃机 |
| KR101375216B1 (ko) * | 2013-10-18 | 2014-03-18 | 김경식 | 유리창 청소 로봇 |
| JP6494118B2 (ja) | 2013-12-19 | 2019-04-03 | アクチエボラゲット エレクトロルックス | 障害物の乗り上げの検出に伴うロボット掃除機の制御方法、並びに、当該方法を有するロボット掃除機、プログラム、及びコンピュータ製品 |
| US10045675B2 (en) | 2013-12-19 | 2018-08-14 | Aktiebolaget Electrolux | Robotic vacuum cleaner with side brush moving in spiral pattern |
| WO2015090397A1 (fr) | 2013-12-19 | 2015-06-25 | Aktiebolaget Electrolux | Dispositif de nettoyage robotique |
| WO2015090404A1 (fr) | 2013-12-19 | 2015-06-25 | Aktiebolaget Electrolux | Priorisation de zones de nettoyage |
| EP3082537B1 (fr) | 2013-12-19 | 2020-11-18 | Aktiebolaget Electrolux | Dispositif de nettoyage robotisé et procédé de reconnaissance de point de repère |
| EP3084538B1 (fr) | 2013-12-19 | 2017-11-01 | Aktiebolaget Electrolux | Dispositif de nettoyage robotisé à fonction d'enregistrement de périmètre |
| ES2675786T3 (es) | 2013-12-19 | 2018-07-12 | Aktiebolaget Electrolux | Control de velocidad adaptativo de cepillo lateral rotatorio |
| CN105848545B (zh) | 2013-12-20 | 2019-02-19 | 伊莱克斯公司 | 灰尘容器 |
| US10518416B2 (en) | 2014-07-10 | 2019-12-31 | Aktiebolaget Electrolux | Method for detecting a measurement error in a robotic cleaning device |
| CA2955223A1 (fr) * | 2014-07-15 | 2016-01-21 | Jerry W. Wilkes | Appareil concu pour l'elimination de matiere etranger |
| CN106659344B (zh) | 2014-09-08 | 2019-10-25 | 伊莱克斯公司 | 机器人真空吸尘器 |
| EP3190939B1 (fr) | 2014-09-08 | 2021-07-21 | Aktiebolaget Electrolux | Aspirateur robot autonomous |
| CN104330479B (zh) * | 2014-11-27 | 2017-01-25 | 长沙理工大学 | 一种用于大型曲面构件的超声相控阵自动扫查装置 |
| WO2016091291A1 (fr) | 2014-12-10 | 2016-06-16 | Aktiebolaget Electrolux | Utilisation d'un capteur laser pour la détection d'un type de sol |
| US10874271B2 (en) | 2014-12-12 | 2020-12-29 | Aktiebolaget Electrolux | Side brush and robotic cleaner |
| EP3234714B1 (fr) | 2014-12-16 | 2021-05-12 | Aktiebolaget Electrolux | Feuille de route basée sur l'expérience pour un dispositif de nettoyage robotisé |
| WO2016095966A1 (fr) | 2014-12-16 | 2016-06-23 | Aktiebolaget Electrolux | Procédé de nettoyage pour un dispositif de nettoyage robotisé |
| US11099554B2 (en) | 2015-04-17 | 2021-08-24 | Aktiebolaget Electrolux | Robotic cleaning device and a method of controlling the robotic cleaning device |
| EP3344104B1 (fr) | 2015-09-03 | 2020-12-30 | Aktiebolaget Electrolux | Système de dispositifs de nettoyage robotisés |
| WO2017157421A1 (fr) | 2016-03-15 | 2017-09-21 | Aktiebolaget Electrolux | Dispositif de nettoyage robotique et procédé au niveau du dispositif de nettoyage robotique pour effectuer une détection de falaise |
| WO2017194102A1 (fr) | 2016-05-11 | 2017-11-16 | Aktiebolaget Electrolux | Dispositif de nettoyage robotisé |
| CN110621208A (zh) | 2017-06-02 | 2019-12-27 | 伊莱克斯公司 | 检测机器人清洁设备前方的表面的高度差的方法 |
| JP6989210B2 (ja) | 2017-09-26 | 2022-01-05 | アクチエボラゲット エレクトロルックス | ロボット清掃デバイスの移動の制御 |
| CN112021983A (zh) * | 2020-09-14 | 2020-12-04 | 山东贝克特智能科技有限公司 | 一种高层建筑玻璃自动清洁装置 |
Citations (3)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| EP0505956A1 (fr) * | 1991-03-29 | 1992-09-30 | Hebor Anstalt | Appareil de nettoyage de surfaces lisses continues |
| EP0541951A1 (fr) * | 1991-10-30 | 1993-05-19 | SYSTEMA S.n.c. | Dispositif pour nettoyer les surfaces extérieures de bâtiments |
| JPH08322763A (ja) * | 1995-06-01 | 1996-12-10 | Ishikawajima Inspection & Instrumentation Co | ガラス窓清掃装置 |
Family Cites Families (7)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| US3641607A (en) * | 1969-03-17 | 1972-02-15 | Jerome H Lemelson | Building maintenance apparatus |
| DE2737619C3 (de) * | 1977-08-20 | 1981-02-05 | Eugen Kloepper Gmbh & Co, 4600 Dortmund | Vorrichtung zum Reinigen von Flächen, insbesondere von durchsichtigen Dachhäuten von Traglufthallen |
| IT1198000B (it) * | 1986-11-14 | 1988-12-21 | Alan Srl | Apparecchiatura per la manutenzione di facciate di edifici particolarmente di facciate con ampie superfici vetrate |
| US5263223A (en) * | 1992-03-02 | 1993-11-23 | Von Schrader Company | Apparatus for cleaning interior surfaces |
| US5465446A (en) * | 1995-01-04 | 1995-11-14 | Chang; Kai-Kuo | High-rise building cleaning machine |
| JP3452416B2 (ja) * | 1995-03-28 | 2003-09-29 | 株式会社大林組 | 屋上清掃ロボット |
| US5715557A (en) * | 1997-01-15 | 1998-02-10 | Hsu; Po-Lin | Machine for automatically cleaning the outer wall of a high-rise building |
-
1998
- 1998-04-03 EP EP98250120A patent/EP0870461A1/fr not_active Withdrawn
- 1998-04-10 US US09/058,637 patent/US5959424A/en not_active Expired - Fee Related
Patent Citations (3)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| EP0505956A1 (fr) * | 1991-03-29 | 1992-09-30 | Hebor Anstalt | Appareil de nettoyage de surfaces lisses continues |
| EP0541951A1 (fr) * | 1991-10-30 | 1993-05-19 | SYSTEMA S.n.c. | Dispositif pour nettoyer les surfaces extérieures de bâtiments |
| JPH08322763A (ja) * | 1995-06-01 | 1996-12-10 | Ishikawajima Inspection & Instrumentation Co | ガラス窓清掃装置 |
Non-Patent Citations (1)
| Title |
|---|
| PATENT ABSTRACTS OF JAPAN vol. 097, no. 004 30 April 1997 (1997-04-30) * |
Cited By (16)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| EP2386364A1 (fr) * | 2010-04-23 | 2011-11-16 | Anton Jäger | Dispositif de nettoyage pour panneaux solaire |
| US8955187B2 (en) | 2010-04-23 | 2015-02-17 | Anton Jaeger | Cleaning apparatus |
| US9559634B2 (en) | 2010-04-23 | 2017-01-31 | Anton Jaeger | Cleaning apparatus |
| CN102228374A (zh) * | 2011-06-14 | 2011-11-02 | 南昌大学 | 用于壁面清洁机器人的清洁单元 |
| CN103084346A (zh) * | 2011-10-28 | 2013-05-08 | 上海久能能源科技发展有限公司 | 一种屋面用太阳能光伏清洗机 |
| CN104224036A (zh) * | 2014-08-29 | 2014-12-24 | 平湖普英特高层设备有限公司 | 擦窗机c型轨电机爬轨器 |
| CN104224036B (zh) * | 2014-08-29 | 2016-04-13 | 平湖普英特高层设备有限公司 | 擦窗机c型轨电机爬轨器 |
| CN106073654A (zh) * | 2016-07-27 | 2016-11-09 | 山东英才学院 | 高层建筑幕墙自动清洗机 |
| CN108324197A (zh) * | 2017-12-29 | 2018-07-27 | 陈玉玲 | 一种高层楼寓外墙擦洗喷涂机器人 |
| CN108724165A (zh) * | 2018-06-21 | 2018-11-02 | 宁波介量机器人技术有限公司 | 一种绳缆约束机器人 |
| CN108724165B (zh) * | 2018-06-21 | 2022-04-19 | 宁波介量机器人技术有限公司 | 一种绳缆约束机器人 |
| CN109674391A (zh) * | 2018-12-28 | 2019-04-26 | 上海石猴智能科技有限公司 | 一种擦玻璃机器人障碍物检测装置及检测方法 |
| CN111035335A (zh) * | 2019-12-18 | 2020-04-21 | 南京驭逡通信科技有限公司 | 一种便于清洁死角的清洁机器人 |
| CN111035335B (zh) * | 2019-12-18 | 2021-05-28 | 南京驭逡通信科技有限公司 | 一种便于清洁死角的清洁机器人 |
| CN112025734A (zh) * | 2020-09-08 | 2020-12-04 | 湖南汉坤实业有限公司 | 一种清洁机器人 |
| CN112025734B (zh) * | 2020-09-08 | 2021-09-07 | 湖南汉坤实业有限公司 | 一种清洁机器人 |
Also Published As
| Publication number | Publication date |
|---|---|
| US5959424A (en) | 1999-09-28 |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| DE69619009T3 (de) | PKW-Transportanlage | |
| DE69006119T2 (de) | Wagen für den Transport eines zylindrischen Gegenstandes. | |
| DE102011001712B4 (de) | Stromabnehmersystem und Anlage | |
| US5959424A (en) | Drive device for moving a robot or vehicle on flat, inclined or curved surfaces, particularly of a glass construction and robot with drive device | |
| DE2023683B2 (de) | Fahrzeug mit magnetischer bodenhaftung | |
| DE102013002020B4 (de) | Wickelungsvorrichtung und Wickelungsverfahren für ein strangförmiges Wickelgut | |
| DE69219429T2 (de) | Bodenflächenstrahlgerät | |
| DE2556484B2 (de) | Kabelwickelmaschine | |
| EP0088868A1 (fr) | Véhicule pour le fond sans rail | |
| DE2211247C3 (de) | Vorrichtung zum vorläufigen Installieren einer Oberleitung oberhalb einer Schienenstrecke mit einem Schienenfahrzeug | |
| DE102013002017A1 (de) | Wickelungsvorrichtung und -verfahren für ein strangförmiges Wickelgut | |
| DE102013002022A1 (de) | Vorrichtung zum Wickeln eines strangförmigen Wickelguts und Verfahren dazu | |
| AT389864B (de) | Fuehrungsvorrichtung fuer ein seil | |
| DE19716741C2 (de) | Vorrichtung zum Reinigen der Flächen einer Glaskonstruktion | |
| DE2431784B2 (de) | Kabelführungsrolle mit Lagerkonstruktion | |
| EP3947230B1 (fr) | Dispositif de bande de mesure pour un insert dans une installation d'ascenseur et procédé d'installation et de fonctionnement d'une installation d'ascenseur | |
| DE4334063C1 (de) | Vorrichtung zum Verlegen von Eisenbahnoberleitungen | |
| DE102010007997A1 (de) | Konzept für die Steuerung einer aus mehreren Segmenten bestehenden verfahrbaren Förderbrücke | |
| DE29622167U1 (de) | Kletterraupe/Kletter-Roboter | |
| EP0706910A1 (fr) | Machine de pose en continu du câble d'alimentation d'un caténaire électrique | |
| DE102013002019A1 (de) | Wickelungsvorrichtung für ein strangförmiges Wickelgut und Verfahren dazu | |
| DE29719865U1 (de) | System zum Steuern der Bewegungen einer Lasthebevorrichtung | |
| DE19716740C1 (de) | Vorrichtung zum Bewegen eines Roboters oder Fahrzeugs auf der Fläche einer Glaskonstruktion | |
| EP0580604A1 (fr) | Installation pour la pose d'un cable, fil ou similaire. | |
| EP1123830B1 (fr) | Méthode et machine pour l'installation d'une ligne caténaire |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| PUAI | Public reference made under article 153(3) epc to a published international application that has entered the european phase |
Free format text: ORIGINAL CODE: 0009012 |
|
| 17P | Request for examination filed |
Effective date: 19980403 |
|
| AK | Designated contracting states |
Kind code of ref document: A1 Designated state(s): AT BE CH DE DK ES FI FR GB GR IE IT LI LU MC NL PT SE |
|
| AX | Request for extension of the european patent |
Free format text: AL;LT;LV;MK;RO;SI |
|
| AKX | Designation fees paid | ||
| STAA | Information on the status of an ep patent application or granted ep patent |
Free format text: STATUS: THE APPLICATION IS DEEMED TO BE WITHDRAWN |
|
| 18D | Application deemed to be withdrawn |
Effective date: 19990415 |