JP5121132B2 - 内視鏡システム、及び内視鏡用操作補助装置 - Google Patents
内視鏡システム、及び内視鏡用操作補助装置 Download PDFInfo
- Publication number
- JP5121132B2 JP5121132B2 JP2005320040A JP2005320040A JP5121132B2 JP 5121132 B2 JP5121132 B2 JP 5121132B2 JP 2005320040 A JP2005320040 A JP 2005320040A JP 2005320040 A JP2005320040 A JP 2005320040A JP 5121132 B2 JP5121132 B2 JP 5121132B2
- Authority
- JP
- Japan
- Prior art keywords
- operation instruction
- insertion portion
- endoscope
- treatment instrument
- treatment
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Expired - Fee Related
Links
Images













Classifications
-
- A—HUMAN NECESSITIES
- A61—MEDICAL OR VETERINARY SCIENCE; HYGIENE
- A61B—DIAGNOSIS; SURGERY; IDENTIFICATION
- A61B1/00—Instruments for performing medical examinations of the interior of cavities or tubes of the body by visual or photographical inspection, e.g. endoscopes; Illuminating arrangements therefor
- A61B1/012—Instruments for performing medical examinations of the interior of cavities or tubes of the body by visual or photographical inspection, e.g. endoscopes; Illuminating arrangements therefor characterised by internal passages or accessories therefor
- A61B1/018—Instruments for performing medical examinations of the interior of cavities or tubes of the body by visual or photographical inspection, e.g. endoscopes; Illuminating arrangements therefor characterised by internal passages or accessories therefor for receiving instruments
-
- A—HUMAN NECESSITIES
- A61—MEDICAL OR VETERINARY SCIENCE; HYGIENE
- A61B—DIAGNOSIS; SURGERY; IDENTIFICATION
- A61B1/00—Instruments for performing medical examinations of the interior of cavities or tubes of the body by visual or photographical inspection, e.g. endoscopes; Illuminating arrangements therefor
- A61B1/00002—Operational features of endoscopes
- A61B1/00039—Operational features of endoscopes provided with input arrangements for the user
- A61B1/00042—Operational features of endoscopes provided with input arrangements for the user for mechanical operation
-
- A—HUMAN NECESSITIES
- A61—MEDICAL OR VETERINARY SCIENCE; HYGIENE
- A61B—DIAGNOSIS; SURGERY; IDENTIFICATION
- A61B1/00—Instruments for performing medical examinations of the interior of cavities or tubes of the body by visual or photographical inspection, e.g. endoscopes; Illuminating arrangements therefor
- A61B1/00131—Accessories for endoscopes
- A61B1/00133—Drive units for endoscopic tools inserted through or with the endoscope
-
- A—HUMAN NECESSITIES
- A61—MEDICAL OR VETERINARY SCIENCE; HYGIENE
- A61B—DIAGNOSIS; SURGERY; IDENTIFICATION
- A61B17/00—Surgical instruments, devices or methods
- A61B17/28—Surgical forceps
- A61B17/29—Forceps for use in minimally invasive surgery
-
- A—HUMAN NECESSITIES
- A61—MEDICAL OR VETERINARY SCIENCE; HYGIENE
- A61B—DIAGNOSIS; SURGERY; IDENTIFICATION
- A61B17/00—Surgical instruments, devices or methods
- A61B17/32—Surgical cutting instruments
- A61B17/3205—Excision instruments
- A61B17/32056—Surgical snare instruments
-
- A—HUMAN NECESSITIES
- A61—MEDICAL OR VETERINARY SCIENCE; HYGIENE
- A61B—DIAGNOSIS; SURGERY; IDENTIFICATION
- A61B17/00—Surgical instruments, devices or methods
- A61B2017/00017—Electrical control of surgical instruments
-
- A—HUMAN NECESSITIES
- A61—MEDICAL OR VETERINARY SCIENCE; HYGIENE
- A61B—DIAGNOSIS; SURGERY; IDENTIFICATION
- A61B17/00—Surgical instruments, devices or methods
- A61B2017/00367—Details of actuation of instruments, e.g. relations between pushing buttons, or the like, and activation of the tool, working tip, or the like
- A61B2017/00371—Multiple actuation, e.g. pushing of two buttons, or two working tips becoming operational
- A61B2017/00376—Simultaneous actuation of two tools by simultaneously pushing two buttons
-
- A—HUMAN NECESSITIES
- A61—MEDICAL OR VETERINARY SCIENCE; HYGIENE
- A61B—DIAGNOSIS; SURGERY; IDENTIFICATION
- A61B17/00—Surgical instruments, devices or methods
- A61B2017/00367—Details of actuation of instruments, e.g. relations between pushing buttons, or the like, and activation of the tool, working tip, or the like
- A61B2017/00371—Multiple actuation, e.g. pushing of two buttons, or two working tips becoming operational
- A61B2017/0038—Simultaneous actuation of two tools by pushing one button or the like
-
- A—HUMAN NECESSITIES
- A61—MEDICAL OR VETERINARY SCIENCE; HYGIENE
- A61B—DIAGNOSIS; SURGERY; IDENTIFICATION
- A61B17/00—Surgical instruments, devices or methods
- A61B2017/00367—Details of actuation of instruments, e.g. relations between pushing buttons, or the like, and activation of the tool, working tip, or the like
- A61B2017/00398—Details of actuation of instruments, e.g. relations between pushing buttons, or the like, and activation of the tool, working tip, or the like using powered actuators, e.g. stepper motors, solenoids
-
- A—HUMAN NECESSITIES
- A61—MEDICAL OR VETERINARY SCIENCE; HYGIENE
- A61B—DIAGNOSIS; SURGERY; IDENTIFICATION
- A61B17/00—Surgical instruments, devices or methods
- A61B2017/0042—Surgical instruments, devices or methods with special provisions for gripping
-
- A—HUMAN NECESSITIES
- A61—MEDICAL OR VETERINARY SCIENCE; HYGIENE
- A61B—DIAGNOSIS; SURGERY; IDENTIFICATION
- A61B17/00—Surgical instruments, devices or methods
- A61B2017/0042—Surgical instruments, devices or methods with special provisions for gripping
- A61B2017/00424—Surgical instruments, devices or methods with special provisions for gripping ergonomic, e.g. fitting in fist
-
- A—HUMAN NECESSITIES
- A61—MEDICAL OR VETERINARY SCIENCE; HYGIENE
- A61B—DIAGNOSIS; SURGERY; IDENTIFICATION
- A61B17/00—Surgical instruments, devices or methods
- A61B2017/0042—Surgical instruments, devices or methods with special provisions for gripping
- A61B2017/00429—Surgical instruments, devices or methods with special provisions for gripping with a roughened portion
- A61B2017/00433—Surgical instruments, devices or methods with special provisions for gripping with a roughened portion knurled
-
- A—HUMAN NECESSITIES
- A61—MEDICAL OR VETERINARY SCIENCE; HYGIENE
- A61B—DIAGNOSIS; SURGERY; IDENTIFICATION
- A61B17/00—Surgical instruments, devices or methods
- A61B2017/0042—Surgical instruments, devices or methods with special provisions for gripping
- A61B2017/00438—Surgical instruments, devices or methods with special provisions for gripping connectable to a finger
-
- A—HUMAN NECESSITIES
- A61—MEDICAL OR VETERINARY SCIENCE; HYGIENE
- A61B—DIAGNOSIS; SURGERY; IDENTIFICATION
- A61B17/00—Surgical instruments, devices or methods
- A61B2017/0046—Surgical instruments, devices or methods with a releasable handle; with handle and operating part separable
- A61B2017/00469—Surgical instruments, devices or methods with a releasable handle; with handle and operating part separable for insertion of instruments, e.g. guide wire, optical fibre
-
- A—HUMAN NECESSITIES
- A61—MEDICAL OR VETERINARY SCIENCE; HYGIENE
- A61B—DIAGNOSIS; SURGERY; IDENTIFICATION
- A61B17/00—Surgical instruments, devices or methods
- A61B2017/00477—Coupling
-
- A—HUMAN NECESSITIES
- A61—MEDICAL OR VETERINARY SCIENCE; HYGIENE
- A61B—DIAGNOSIS; SURGERY; IDENTIFICATION
- A61B17/00—Surgical instruments, devices or methods
- A61B17/22—Implements for squeezing-off ulcers or the like on inner organs of the body; Implements for scraping-out cavities of body organs, e.g. bones; for invasive removal or destruction of calculus using mechanical vibrations; for removing obstructions in blood vessels, not otherwise provided for
- A61B2017/22072—Implements for squeezing-off ulcers or the like on inner organs of the body; Implements for scraping-out cavities of body organs, e.g. bones; for invasive removal or destruction of calculus using mechanical vibrations; for removing obstructions in blood vessels, not otherwise provided for with an instrument channel, e.g. for replacing one instrument by the other
- A61B2017/22074—Implements for squeezing-off ulcers or the like on inner organs of the body; Implements for scraping-out cavities of body organs, e.g. bones; for invasive removal or destruction of calculus using mechanical vibrations; for removing obstructions in blood vessels, not otherwise provided for with an instrument channel, e.g. for replacing one instrument by the other the instrument being only slidable in a channel, e.g. advancing optical fibre through a channel
- A61B2017/22075—Implements for squeezing-off ulcers or the like on inner organs of the body; Implements for scraping-out cavities of body organs, e.g. bones; for invasive removal or destruction of calculus using mechanical vibrations; for removing obstructions in blood vessels, not otherwise provided for with an instrument channel, e.g. for replacing one instrument by the other the instrument being only slidable in a channel, e.g. advancing optical fibre through a channel with motorized advancing or retracting means
-
- A—HUMAN NECESSITIES
- A61—MEDICAL OR VETERINARY SCIENCE; HYGIENE
- A61B—DIAGNOSIS; SURGERY; IDENTIFICATION
- A61B17/00—Surgical instruments, devices or methods
- A61B17/34—Trocars; Puncturing needles
- A61B17/3403—Needle locating or guiding means
- A61B2017/3405—Needle locating or guiding means using mechanical guide means
- A61B2017/3409—Needle locating or guiding means using mechanical guide means including needle or instrument drives
-
- A—HUMAN NECESSITIES
- A61—MEDICAL OR VETERINARY SCIENCE; HYGIENE
- A61B—DIAGNOSIS; SURGERY; IDENTIFICATION
- A61B34/00—Computer-aided surgery; Manipulators or robots specially adapted for use in surgery
- A61B34/30—Surgical robots
- A61B2034/301—Surgical robots for introducing or steering flexible instruments inserted into the body, e.g. catheters or endoscopes
-
- A—HUMAN NECESSITIES
- A61—MEDICAL OR VETERINARY SCIENCE; HYGIENE
- A61B—DIAGNOSIS; SURGERY; IDENTIFICATION
- A61B34/00—Computer-aided surgery; Manipulators or robots specially adapted for use in surgery
- A61B34/70—Manipulators specially adapted for use in surgery
- A61B34/74—Manipulators with manual electric input means
- A61B2034/742—Joysticks
Landscapes
- Health & Medical Sciences (AREA)
- Life Sciences & Earth Sciences (AREA)
- Surgery (AREA)
- Engineering & Computer Science (AREA)
- Biomedical Technology (AREA)
- Molecular Biology (AREA)
- Pathology (AREA)
- Radiology & Medical Imaging (AREA)
- Nuclear Medicine, Radiotherapy & Molecular Imaging (AREA)
- Biophysics (AREA)
- Physics & Mathematics (AREA)
- Heart & Thoracic Surgery (AREA)
- Medical Informatics (AREA)
- Optics & Photonics (AREA)
- Animal Behavior & Ethology (AREA)
- General Health & Medical Sciences (AREA)
- Public Health (AREA)
- Veterinary Medicine (AREA)
- Mechanical Engineering (AREA)
- Endoscopes (AREA)
- Instruments For Viewing The Inside Of Hollow Bodies (AREA)
- Surgical Instruments (AREA)
Description
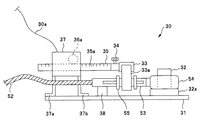
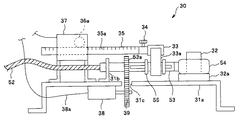
先ず、図1〜図11を用いて、本発明の第1の実施の形態について説明する。尚、図1〜図11は、本発明の第1の実施の形態に係り、図1は内視鏡システムを示す全体構成図、図2は操作指示装置を示す図、図3は操作指示装置を側面から見た平面図、図4は操作指示装置の第1の変形例を示し、操作指示装置を側面から見た平面図、図5は操作指示装置の第2の変形例を示し、操作指示装置を側面から見た平面図、図6は処置具電動進退装置の内部構成を示す縦方向の断面図、図7は処置具電動進退装置の内部構成を示す横方向の断面図、図8は処置具電動開閉装置を上方から見た平面図、図9は処置具電動開閉装置を側方から見た平面図、図10は内視鏡の挿入部に操作指示装置が装着された状態を示す図、図11は操作指示装置による処置具の操作一例を説明するための図である。
この内視鏡10は、処置具挿通部12dから先端部11aにかけて図示しない処置具チャンネルを有している。
また、処置具電動進退装置40は、電気ケーブル40aによって、制御装置20と電気的に接続され、内視鏡10の処置具挿通部12dに設置される。この処置具電動進退装置40には、処置具50のシース52を処置具チャンネルに導くように挿入される。
操作指示装置45は、信号ケーブル45aによって、制御装置20と電気的に接続され、内視鏡10の挿入部11に外挿される。
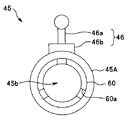
図2に示すように、操作指示装置45は、挿入部挿通孔45bを有する略円筒状の挿入部挿通体としての挿入部外挿管45Aを有しており、この挿入部外挿管45Aの先端側の外周面に操作レバー46a、及び操作レバー支持部46bからなる操作指示部46が設けられている。この操作指示部46の操作レバー支持部46bからは、上述の信号ケーブル45aが延設されている。
図6に示すように、処置具電動進退装置40は、箱体41の内部に2つのローラ43a,43bが回動自在に設けられている。この箱体41には、一面に処置具50のシース52が挿入される処置具挿入部42と、該一面と反対側に前記シース52を内視鏡10の処置具チャンネルへと導き、内視鏡10の処置具挿通部12dに接続するスコープ固定部41aと、が設けられている。
図8、及び図9に示すように、処置具電動開閉装置30は、板状のベース体31と、このベース体31の一面に突設されたリング押さえ部32と、処置具50のスライダ55を挟持するスライダ押さえ部33と、このスライダ押さえ部33と連結されるラック35と、ラック35の直線歯形35aと噛み合うピニオンギア36aがモータ軸に取り付けられたモータ36と、固定部材37a,37bによりベース体31に固定され、モータ36のピニオンギア36aを収容すると共に、ラック35を進退自在に直進保持する保持ボックス37と、ベース体31の前記一面に配され、処置具50のハンドル部53が載置される載置部38と、を有して構成される。
次に、図12〜図15を用いて、本発明の第2の実施の形態について説明する。尚、図12〜図15は、本発明の第2の実施の形態に係り、図12は内視鏡システムを示す全体構成図、図13は処置具電動開閉装置を側方から見た平面図、図14は、操作指示装置を示す図、図15は操作指示装置による処置具の操作一例を説明するための図である。
次に、図16、及び図17を用いて、本発明の第3の実施の形態について説明する。尚、図16、及び図17は、本発明の第3の実施の形態に係り、図16は内視鏡システムを示す全体構成図、図17は操作指示装置の湾曲指示部の操作により内視鏡の湾曲部を湾曲する作用を説明する図である。また、本実施の形態の内視鏡システムの説明においても、第1の実施の形態に記載した各構成と同じ構成については、同じ符号を使用して、それらの詳細な説明を省略する。
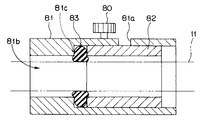
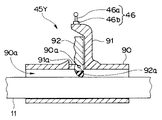
次に、図18、及び図19を用いて、本発明の第4の実施の形態について説明する。尚、図18、及び図19は、本発明の第4の実施の形態に係り、内視鏡の挿入部に装着される操作指示装置の断面を示し、折れ止め部に保持する保持手段を説明するための図である。
次に、図20〜図22を用いて、本発明の第5の実施の形態について説明する。尚、図20〜図22は、本発明の第5の実施の形態に係り、図20は本実施の形態の内視鏡システム1を示す全体構成図、図21は操作指示装置を上方から見た平面図、図22は操作指示装置の操作指示部を示す斜視図である。
次に、図23〜図26を用いて、本発明の第6の実施の形態について説明する。図23〜図26は、本発明の第6の実施の形態に係り、図23は内視鏡の挿入部に装着された操作指示装置を示す斜視図、図24は内視鏡の挿入部に装着された操作指示装置を示す断面図、図25は内視鏡の挿入部に装着された操作指示装置の変形例を示す斜視図、図26は図25の操作指示装置を基端側から見た平面図である。
軟性グリップ60は、その内径が内視鏡10の挿入部11の外径よりも大きな貫通孔を有しており、挿入部11が挿通自在となっている。
次に、図27〜図30を用いて、本発明の第7の実施の形態について説明する。図27〜図30は、本発明の第7の実施の形態に係り、図27は内視鏡の挿入部に装着された操作指示装置を示す斜視図、図28は内視鏡の挿入部に装着された操作指示装置を示す断面図、図29は内視鏡の挿入部に装着された操作指示装置の作用を説明するための断面図、図30は操作指示装置の変形例を示し、操作指示装置を上方から見た平面図である。
次に、図31〜図34を用いて、本発明の第8の実施の形態について説明する。尚、本実施の形態でも、上述の各実施の形態で記載した操作指示装置と同じ各構成について、同じ符号を使って、その詳細な説明を省略する。
また、図31〜図34は、本発明の第8の実施の形態に係り、図31は操作指示装置を示す斜視図、図32は図31の操作指示装置を内視鏡の挿入部への装着する作用を説明する図、図33は本実施の形態の変形例となる内視鏡の挿入部に装着された操作指示装置を示す斜視図、図34は図33の操作指示装置を内視鏡の挿入部への装着する作用を説明する図である。
次に、図35〜図37を用いて、本発明の第9の実施の形態について説明する。尚、本実施の形態でも、上述の各実施の形態で記載した操作指示装置と同じ各構成について、同じ符号を使って、その詳細な説明を省略する。
また、図35〜図37は、本発明の第9の実施の形態に係り、図35は操作指示装置を示す斜視図、図36、及び図37は内視鏡の挿入部に操作指示装置を装着した状態を示す断面図である。
次に、図38〜図40を用いて、本発明の第10の実施の形態について説明する。尚、本実施の形態でも、上述の各実施の形態で記載した操作指示装置と同じ各構成について、同じ符号を使って、その詳細な説明を省略する。
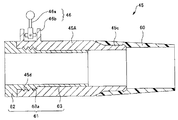
また、図38〜図40は、本発明の第10の実施の形態に係り、図38は操作指示装置及び、この操作指示装置に装着される複数のスペーサを示す斜視図、図39は操作指示装置と装着前のスペーサを示す断面図、図40はスペーサが装着された操作指示装置の断面図である。
これら3つのスペーサ61は、夫々が略筒状をしており、挿入部外挿管45Aと略同じ外径を備えた先端部62と、この先端部62の基端に配設され、挿入部挿通孔45bの孔径と略同じ外径を備えた接続部63と、から構成されている。接続部63の外周面には、挿入部外挿管45Aの内周面に形成されたネジ溝45d(図39参照)と螺合するネジ溝63aが形成されている。
次に、図41〜図45を用いて、本発明の第11の実施の形態について説明する。尚、本実施の形態でも、上述の各実施の形態で記載した操作指示装置と同じ各構成について、同じ符号を使って、その詳細な説明を省略する。
また、図41〜図45は、本発明の第11の実施の形態に係り、図41は操作指示装置の分解斜視図、図42は操作指示装置の断面図、図43は操作指示装置の斜視図、図44は操作指示装置の断面図、図45は操作指示装置の斜視図である。
次に、図46、及び図47を用いて、本発明の第12の実施の形態について説明する。尚、本実施の形態でも、上述の各実施の形態で記載した操作指示装置と同じ各構成について、同じ符号を使って、その詳細な説明を省略する。
また、図46、及び図47は、本発明の第12の実施の形態に係り、図46は操作指示装置を示す斜視図、図47は、操作指示装置を側方から見た平面図である。
取付けリング67には、外周部に配設された操作指示部46の略反対側の外周部分に固定ネジである止ネジ67aが貫通するように螺着されている。この止ネジ67aは、取付けリング67に対する螺合量に応じて、挿入部挿通体66の外周面を端面で押圧し、取付けリング67を挿入部挿通体66に固定する。
次に、図48、及び図49を用いて、本発明の第13の実施の形態について説明する。尚、本実施の形態でも、上述の各実施の形態で記載した操作指示装置と同じ各構成について、同じ符号を使って、その詳細な説明を省略する。
また、図48、及び図49は、本発明の本実施の形態に係り、図48は、操作指示装置を示す斜視図、図49は、操作指示装置が術者の指に装着され、内視鏡の挿入部が把持された状態を示す図である。
次に、図50〜図53を用いて、本発明の第13の実施の形態について説明する。尚、本実施の形態でも、上述の各実施の形態で記載した操作指示装置と同じ各構成について、同じ符号を使って、その詳細な説明を省略する。
また、図50〜図53は、本発明の第14の実施の形態に係り、図50は内視鏡の挿入部に外挿する操作指示装置を示す図、図51は図50の操作指示装置を示す断面図、図52は操作指示装置の作用を説明するための断面、図53は操作指示装置の作用を説明するための図である。
10・・・内視鏡
11・・・挿入部
11b・・・湾曲部
12・・・操作部
20・・・制御装置
21・・・高周波電源装置
26・・・操作指示部
30・・・処置具電動開閉装置
40・・・処置具電動進退装置
42・・・処置具挿入部
45・・・操作指示装置
46・・・操作指示部
50・・・処置具
51・・・処置部
52・・・シース
55・・・スライダ
Claims (16)
- 撮像光学系、照明光学系、及び湾曲部が先端部分に配設された長尺な挿入部を備えた内視鏡と、
上記挿入部に装着され、且つ該挿入部の軸に沿って進退移動自在であり、上記内視鏡と併用される処置具の操作を指示可能な操作指示装置と、
該操作指示装置に設けられて上記処置具を傾倒操作により指示する操作レバーと、
上記処置具のシースを上記内視鏡の処置具チャンネル内で進退移動させる処置具電動進退装置と、
上記処置具の処置部の開閉操作を行う処置具電動開閉装置と、
上記操作指示装置から入力される上記操作レバーの傾倒方向および角度に応じた指示信号に基づき、上記処置具電動進退装置および上記処置具電動開閉装置を駆動制御して上記シースの進退速度および上記処置部の開閉速度を変更する制御部と、
を具備することを特徴とした内視鏡システム。 - 上記操作指示装置は、上記挿入部が挿通可能であって、上記操作レバーが外周部に設けられた管状の挿入部挿通体を有していることを特徴とする請求項1に記載の内視鏡システム。
- さらに、上記操作指示装置は、上記挿入部挿通体における上記操作レバーの反対側の外周部に配設され、上記処置具の上記処置部の長軸回りへの回動操作を指示可能な回動操作レバーを有し、
上記処置具電動開閉装置は、上記処置具を長手軸回りに回動させる駆動部を有し、上記回動操作レバーの傾倒角度に応じた指示信号に基づいて、上記処置部の回転速度が変更するように上記制御部に駆動制御される回動機構を備えていることを特徴とする請求項2に記載の内視鏡システム。 - 上記操作レバーは、上記挿入部が上記挿入部挿通体に挿通した状態における上記先端部分側となる先端側の位置に配設されていることを特徴とする請求項2または請求項3に記載の内視鏡システム。
- 上記操作指示装置は、上記挿入部が上記挿入部挿通体に挿通した状態における基端側となる位置にグリップを有していることを特徴とする請求項4に記載の内視鏡システム。
- 上記グリップは、弾性変形可能であることを特徴とする請求項5に記載の内視鏡システム。
- 上記グリップは、筒体であることを特徴とする請求項5または請求項6に記載の内視鏡システム。
- 上記グリップには、上記筒体の基端から長手軸に沿って所定の長さのスリットが形成されていることを特徴とする請求項7に記載の内視鏡システム。
- 上記操作指示装置は、上記挿入部に固定するための固定手段を備えていることを特徴とする請求項1から請求項8のいずれか1項に記載の内視鏡システム。
- 上記挿入部挿通体は、略筒体が軸方向に沿って分割された第1の部材と第2の部材からなり、
上記第1の部材は、上記内視鏡の上記挿入部を配置可能な凹部を有し、
上記第2の部材は、上記挿入部を覆う位置に上記第1の部材に対して開閉自在に設けられていることを特徴とする請求項2から請求項4のいずれか1項に記載の内視鏡システム。 - 上記挿入部挿通体は、上記第1の部材および上記第2の部材の夫々の側端部が回動自在に連結され、略筒状となる閉状態を保持するように、バネにより付勢されていることを特徴とする請求項10に記載の内視鏡システム。
- 上記操作指示装置は、上記挿入部挿通体の開口部に螺合して着脱自在な複数のスペーサを有し、
該複数のスペーサは、夫々が異なる上記内視鏡の上記挿入部の外径に応じた孔径が設定された孔部を有していることを特徴とする請求項2から請求項4のいずれか1項に記載の内視鏡システム。 - 上記操作指示装置は、
上記挿入部挿通体の長手軸方向にスライド自在なスライド管と、
上記挿入部挿通体に螺着すると共に、該スライド管を上記挿入部挿通体に固定する固定管と、
を有することを特徴とする請求項2から請求項9のいずれか1項に記載の内視鏡システム。 - 内視鏡の挿入部に装着され、且つ該挿入部の軸に沿って進退移動自在であり、該内視鏡と併用される処置具の操作を指示可能な操作指示装置と、
該操作指示装置に設けられて上記処置具を傾倒操作により指示する操作レバーと、
上記処置具のシースを上記内視鏡の処置具チャンネル内で進退移動させる処置具電動進退装置と、
上記処置具の処置部の開閉操作を行う処置具電動開閉装置と、
上記操作指示装置から入力される上記操作レバーの傾倒方向および角度に応じた指示信号に基づき、上記処置具電動進退装置および上記処置具電動開閉装置を駆動制御して上記シースの進退速度および上記処置部の開閉速度を変更する制御部と、
を具備することを特徴とした内視鏡用操作補助装置。 - 上記操作指示装置は、上記挿入部が挿通可能であって、上記操作レバーが外周部に設けられた管状の挿入部挿通体を有していることを特徴とする請求項14に記載の内視鏡用操作補助装置。
- さらに、上記操作指示装置は、上記挿入部挿通体における上記操作レバーの反対側の外周部に配設され、上記処置具の上記処置部の長軸回りへの回動操作を指示可能な回動操作レバーを有し、
処置具電動開閉装置は、上記処置具を長手軸回りに回動させる駆動部を有し、上記回動操作レバーの傾倒角度に応じた指示信号に基づいて、上記処置部の回転速度が変更するように上記制御部に駆動制御される回動機構を備えていることを特徴とする請求項15に記載の内視鏡用操作補助装置。
Priority Applications (4)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| JP2005320040A JP5121132B2 (ja) | 2005-11-02 | 2005-11-02 | 内視鏡システム、及び内視鏡用操作補助装置 |
| US11/592,094 US7871371B2 (en) | 2005-11-02 | 2006-11-02 | Endoscope system equipped with manipulating unit for commanding medical therapy to endoscope and medical instrument attached thereto |
| CN200610143193A CN100586362C (zh) | 2005-11-02 | 2006-11-02 | 内窥镜系统、内窥镜用操作辅助装置 |
| EP06022874A EP1782744B1 (en) | 2005-11-02 | 2006-11-02 | Endoscope system with a manipulating unit detachably and slidably attached to the insertion tube |
Applications Claiming Priority (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| JP2005320040A JP5121132B2 (ja) | 2005-11-02 | 2005-11-02 | 内視鏡システム、及び内視鏡用操作補助装置 |
Publications (2)
| Publication Number | Publication Date |
|---|---|
| JP2007125180A JP2007125180A (ja) | 2007-05-24 |
| JP5121132B2 true JP5121132B2 (ja) | 2013-01-16 |
Family
ID=37698032
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| JP2005320040A Expired - Fee Related JP5121132B2 (ja) | 2005-11-02 | 2005-11-02 | 内視鏡システム、及び内視鏡用操作補助装置 |
Country Status (4)
| Country | Link |
|---|---|
| US (1) | US7871371B2 (ja) |
| EP (1) | EP1782744B1 (ja) |
| JP (1) | JP5121132B2 (ja) |
| CN (1) | CN100586362C (ja) |
Families Citing this family (116)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| US9084621B2 (en) | 2006-12-01 | 2015-07-21 | Boston Scientific Scimed, Inc. | Guide tube systems and methods |
| US7655004B2 (en) | 2007-02-15 | 2010-02-02 | Ethicon Endo-Surgery, Inc. | Electroporation ablation apparatus, system, and method |
| US20080262293A1 (en) * | 2007-04-19 | 2008-10-23 | Olympus Medical Systems Corp | Endoscopic operation assisting device |
| JP5047689B2 (ja) * | 2007-05-17 | 2012-10-10 | オリンパスメディカルシステムズ株式会社 | 電動湾曲内視鏡 |
| WO2008144077A1 (en) | 2007-05-18 | 2008-11-27 | Boston Scientific Scimed, Inc. | Drive systems and methods of use |
| US8105230B2 (en) * | 2007-07-09 | 2012-01-31 | Olympus Medical Systems Corp. | Medical system |
| US8529554B2 (en) * | 2007-09-05 | 2013-09-10 | Olympus Medical Systems Corp. | Treatment instrument operation unit and medical system with treatment instrument operation unit |
| JP5237608B2 (ja) * | 2007-10-25 | 2013-07-17 | オリンパスメディカルシステムズ株式会社 | 医療装置 |
| US20090137872A1 (en) * | 2007-11-27 | 2009-05-28 | Tyco Healthcare Group Lp | Method and Apparatus for Controlling Endoscopic Instruments |
| US8333689B2 (en) * | 2008-05-13 | 2012-12-18 | Olympus Medical Systems Corp. | Medical operation device |
| US8409079B2 (en) * | 2008-05-14 | 2013-04-02 | Olympus Medical Systems Corp. | Electric bending operation device and medical treatment system including electric bending operation device |
| FR2931599A1 (fr) * | 2008-05-26 | 2009-11-27 | Univ Pasteur | Dispositif de deplacement controle en translation d'un element allonge |
| US8888792B2 (en) | 2008-07-14 | 2014-11-18 | Ethicon Endo-Surgery, Inc. | Tissue apposition clip application devices and methods |
| US8157834B2 (en) | 2008-11-25 | 2012-04-17 | Ethicon Endo-Surgery, Inc. | Rotational coupling device for surgical instrument with flexible actuators |
| US8361066B2 (en) | 2009-01-12 | 2013-01-29 | Ethicon Endo-Surgery, Inc. | Electrical ablation devices |
| EP2578178A3 (de) * | 2009-04-28 | 2014-12-31 | Brainlab AG | Verfahren zur Ansteuerung einer behandlungsunterstützenden Software |
| US8086327B2 (en) * | 2009-05-14 | 2011-12-27 | Mks Instruments, Inc. | Methods and apparatus for automated predictive design space estimation |
| US20100292533A1 (en) * | 2009-05-14 | 2010-11-18 | Terumo Cardiovascular Systems Corporation | Endoscopic Cutter with Reconfigurable Guides |
| US20100292532A1 (en) * | 2009-05-14 | 2010-11-18 | Terumo Cardiovascular Systems Corporation | Endoscopic Vessel Dissector With Side Entry |
| JP5543733B2 (ja) * | 2009-06-30 | 2014-07-09 | 大輔 菊池 | 内視鏡用処置具挿通具 |
| US20110098704A1 (en) | 2009-10-28 | 2011-04-28 | Ethicon Endo-Surgery, Inc. | Electrical ablation devices |
| US9028483B2 (en) | 2009-12-18 | 2015-05-12 | Ethicon Endo-Surgery, Inc. | Surgical instrument comprising an electrode |
| US8465488B2 (en) * | 2010-03-16 | 2013-06-18 | Olympus Medical Systems Corporation | Endoscopic surgical instrument |
| CN101926662B (zh) * | 2010-08-05 | 2011-12-28 | 成都军区昆明总医院 | 一种基于内窥镜的强酸碎石设备 |
| US9233241B2 (en) | 2011-02-28 | 2016-01-12 | Ethicon Endo-Surgery, Inc. | Electrical ablation devices and methods |
| US9254169B2 (en) | 2011-02-28 | 2016-02-09 | Ethicon Endo-Surgery, Inc. | Electrical ablation devices and methods |
| WO2012125785A1 (en) | 2011-03-17 | 2012-09-20 | Ethicon Endo-Surgery, Inc. | Hand held surgical device for manipulating an internal magnet assembly within a patient |
| WO2013028381A1 (en) * | 2011-08-19 | 2013-02-28 | Cook Medical Technologies Llc | Cap for attachment to an endoscope |
| WO2013040175A2 (en) * | 2011-09-13 | 2013-03-21 | Tyco Health Care Group Lp | Operative element support structure and method |
| KR20130059150A (ko) | 2011-11-28 | 2013-06-05 | 삼성전자주식회사 | 내시경용 대물 렌즈, 포커싱을 위한 액츄에이터 및 내시경 시스템 |
| US9427255B2 (en) | 2012-05-14 | 2016-08-30 | Ethicon Endo-Surgery, Inc. | Apparatus for introducing a steerable camera assembly into a patient |
| US20130317519A1 (en) | 2012-05-25 | 2013-11-28 | Hansen Medical, Inc. | Low friction instrument driver interface for robotic systems |
| CN104379046B (zh) * | 2012-06-13 | 2017-08-15 | 奥林巴斯株式会社 | 旋转单元和插入装置 |
| US9078662B2 (en) | 2012-07-03 | 2015-07-14 | Ethicon Endo-Surgery, Inc. | Endoscopic cap electrode and method for using the same |
| US9545290B2 (en) | 2012-07-30 | 2017-01-17 | Ethicon Endo-Surgery, Inc. | Needle probe guide |
| US10314649B2 (en) | 2012-08-02 | 2019-06-11 | Ethicon Endo-Surgery, Inc. | Flexible expandable electrode and method of intraluminal delivery of pulsed power |
| US9572623B2 (en) | 2012-08-02 | 2017-02-21 | Ethicon Endo-Surgery, Inc. | Reusable electrode and disposable sheath |
| US9277957B2 (en) | 2012-08-15 | 2016-03-08 | Ethicon Endo-Surgery, Inc. | Electrosurgical devices and methods |
| JP6140950B2 (ja) * | 2012-08-30 | 2017-06-07 | オリンパス株式会社 | 医療用システム |
| US20140155693A1 (en) * | 2012-12-05 | 2014-06-05 | Izhak Fabian | Endoscopic delivery system |
| EP2950738A4 (en) * | 2013-01-29 | 2016-10-26 | Olympus Corp | MEDICAL DEVICE |
| US10098527B2 (en) * | 2013-02-27 | 2018-10-16 | Ethidcon Endo-Surgery, Inc. | System for performing a minimally invasive surgical procedure |
| US11213363B2 (en) | 2013-03-14 | 2022-01-04 | Auris Health, Inc. | Catheter tension sensing |
| US9326822B2 (en) | 2013-03-14 | 2016-05-03 | Hansen Medical, Inc. | Active drives for robotic catheter manipulators |
| US20140277334A1 (en) | 2013-03-14 | 2014-09-18 | Hansen Medical, Inc. | Active drives for robotic catheter manipulators |
| US9173713B2 (en) | 2013-03-14 | 2015-11-03 | Hansen Medical, Inc. | Torque-based catheter articulation |
| US20140276936A1 (en) | 2013-03-15 | 2014-09-18 | Hansen Medical, Inc. | Active drive mechanism for simultaneous rotation and translation |
| US20140276647A1 (en) | 2013-03-15 | 2014-09-18 | Hansen Medical, Inc. | Vascular remote catheter manipulator |
| US9408669B2 (en) | 2013-03-15 | 2016-08-09 | Hansen Medical, Inc. | Active drive mechanism with finite range of motion |
| JP6257174B2 (ja) * | 2013-05-31 | 2018-01-10 | オリンパス株式会社 | 内視鏡装置 |
| US20160278810A1 (en) * | 2013-05-31 | 2016-09-29 | Mark Edmund Richey | Vaginal surgical apparatus |
| US10166044B1 (en) | 2013-05-31 | 2019-01-01 | Freshwater Bay Industries, Llc | Apparatus for repositioning the vagina, cervix, uterus and pelvic floor and method to secure same |
| JP6245877B2 (ja) * | 2013-07-26 | 2017-12-13 | オリンパス株式会社 | 内視鏡処置具用操作入力装置 |
| JP6242101B2 (ja) * | 2013-07-26 | 2017-12-06 | オリンパス株式会社 | 医療装置および医療システム |
| JP6053701B2 (ja) * | 2013-10-22 | 2016-12-27 | オリンパス株式会社 | マニピュレータシステムの制御方法およびマニピュレータシステム |
| CN105939647B (zh) | 2013-10-24 | 2020-01-21 | 奥瑞斯健康公司 | 机器人辅助腔内外科手术系统及相关方法 |
| CN105555184B (zh) * | 2013-10-31 | 2017-05-24 | 夏普株式会社 | 体内监视摄像机系统 |
| EP3613353B1 (en) | 2014-02-07 | 2023-04-26 | Teleflex Life Sciences Limited | Assistive device for removing a biological sample from an intraosseous device |
| JP6234267B2 (ja) * | 2014-02-21 | 2017-11-22 | オリンパス株式会社 | 手術用マニピュレータ操作装置および手術用マニピュレータシステム |
| DK2910204T3 (en) * | 2014-02-24 | 2016-08-22 | S & T Ag | Medical instrument |
| US10046140B2 (en) | 2014-04-21 | 2018-08-14 | Hansen Medical, Inc. | Devices, systems, and methods for controlling active drive systems |
| US10569052B2 (en) | 2014-05-15 | 2020-02-25 | Auris Health, Inc. | Anti-buckling mechanisms for catheters |
| JP6203132B2 (ja) * | 2014-06-17 | 2017-09-27 | オリンパス株式会社 | ガイド装置および手術システム |
| JP6238844B2 (ja) | 2014-06-17 | 2017-11-29 | オリンパス株式会社 | 手術用マニピュレータ操作装置および手術用マニピュレータシステム |
| BR112016030288A2 (pt) * | 2014-06-26 | 2017-08-22 | Taryag Medical Ltd | Sistema de controle remoto para uso em operações localizadas intraluminalmente ou intravascularmente, e, método para controlar remotamente um dispositivo de ativação |
| US9561083B2 (en) | 2014-07-01 | 2017-02-07 | Auris Surgical Robotics, Inc. | Articulating flexible endoscopic tool with roll capabilities |
| CN104644241B (zh) * | 2014-09-12 | 2017-04-05 | 密雷 | 一种微创保胆手术粘膜结石取出系统 |
| US10813708B2 (en) | 2014-12-16 | 2020-10-27 | Koninklijke Philips N.V. | Remote robotic actuation of a transesophageal echocardiography probe |
| AU2016321332B2 (en) | 2015-09-09 | 2020-10-08 | Auris Health, Inc. | Instrument device manipulator for a surgical robotics system |
| US12207863B2 (en) | 2015-10-29 | 2025-01-28 | Innoblative Designs, Inc. | Screen sphere tissue ablation devices and methods |
| US9949749B2 (en) | 2015-10-30 | 2018-04-24 | Auris Surgical Robotics, Inc. | Object capture with a basket |
| US9955986B2 (en) | 2015-10-30 | 2018-05-01 | Auris Surgical Robotics, Inc. | Basket apparatus |
| US10639108B2 (en) | 2015-10-30 | 2020-05-05 | Auris Health, Inc. | Process for percutaneous operations |
| JP6747800B2 (ja) * | 2015-12-04 | 2020-08-26 | オリンパス株式会社 | 処置具挿通具 |
| TWI616179B (zh) * | 2016-02-24 | 2018-03-01 | 克力邁醫材股份有限公司 | 內視鏡裝置 |
| EP3437540B1 (en) * | 2016-03-31 | 2021-11-03 | Keio University | Endoscope holder with gripping members and with elastic members |
| WO2017169279A1 (ja) * | 2016-03-31 | 2017-10-05 | 学校法人慶應義塾 | 内視鏡ホルダー |
| US10454347B2 (en) | 2016-04-29 | 2019-10-22 | Auris Health, Inc. | Compact height torque sensing articulation axis assembly |
| US11241559B2 (en) | 2016-08-29 | 2022-02-08 | Auris Health, Inc. | Active drive for guidewire manipulation |
| EP3506836B1 (en) | 2016-08-31 | 2024-10-02 | Auris Health, Inc. | Length conservative surgical instrument |
| WO2018040061A1 (zh) * | 2016-09-02 | 2018-03-08 | 杭州安杰思医学科技有限公司 | 一种内镜用组织切开装置 |
| EP3538000A4 (en) | 2016-11-08 | 2020-04-01 | Innoblative Designs, Inc. | VESSEL AND ELECTROSURGICAL TISSUE SEALING DEVICE |
| US10244926B2 (en) | 2016-12-28 | 2019-04-02 | Auris Health, Inc. | Detecting endolumenal buckling of flexible instruments |
| GB201701758D0 (en) * | 2017-02-02 | 2017-03-22 | Majeed Ali Waqar | Drive apparatus |
| JP6744831B2 (ja) * | 2017-02-22 | 2020-08-19 | 富士フイルム株式会社 | 処置具チャンネル及び内視鏡 |
| US11026758B2 (en) | 2017-06-28 | 2021-06-08 | Auris Health, Inc. | Medical robotics systems implementing axis constraints during actuation of one or more motorized joints |
| JP6895823B2 (ja) * | 2017-06-30 | 2021-06-30 | オリンパス株式会社 | 内視鏡用リモートコントローラ |
| KR101993373B1 (ko) * | 2017-07-18 | 2019-06-26 | 원텍 주식회사 | 수술용 내시경의 핸들 구조 |
| WO2019023328A1 (en) | 2017-07-26 | 2019-01-31 | Innoblative Designs, Inc. | MINIMALLY INVASIVE JOINT ASSEMBLY HAVING ABLATION CAPABILITIES |
| WO2019118368A1 (en) | 2017-12-11 | 2019-06-20 | Auris Health, Inc. | Systems and methods for instrument based insertion architectures |
| JP7322026B2 (ja) | 2017-12-14 | 2023-08-07 | オーリス ヘルス インコーポレイテッド | 器具の位置推定のシステムおよび方法 |
| US10888386B2 (en) | 2018-01-17 | 2021-01-12 | Auris Health, Inc. | Surgical robotics systems with improved robotic arms |
| IT201800004478A1 (it) * | 2018-04-13 | 2019-10-13 | Sistema di comando per dispositivo medico utilizzabile nell’ambito di un endoscopio. | |
| EP3813632B1 (en) * | 2018-06-27 | 2026-04-22 | Auris Health, Inc. | Alignment and attachment systems for medical instruments |
| US10820947B2 (en) | 2018-09-28 | 2020-11-03 | Auris Health, Inc. | Devices, systems, and methods for manually and robotically driving medical instruments |
| WO2020197671A1 (en) | 2019-03-22 | 2020-10-01 | Auris Health, Inc. | Systems and methods for aligning inputs on medical instruments |
| DE102019111347B4 (de) | 2019-05-02 | 2023-01-26 | Karl Storz Se & Co. Kg | Endoskopische Vorrichtung |
| WO2020236691A1 (en) * | 2019-05-20 | 2020-11-26 | Innoblative Designs, Inc. | Minimally invasive assembly for lung ablation |
| EP3989794A4 (en) | 2019-06-28 | 2023-07-12 | Auris Health, Inc. | PATIENT INTRODUCER FOR A ROBOTIC SYSTEM |
| US11896330B2 (en) | 2019-08-15 | 2024-02-13 | Auris Health, Inc. | Robotic medical system having multiple medical instruments |
| CN114364299B (zh) * | 2019-09-17 | 2025-08-22 | 奥林巴斯株式会社 | 插入设备和内窥镜 |
| WO2021064536A1 (en) | 2019-09-30 | 2021-04-08 | Auris Health, Inc. | Medical instrument with capstan |
| CN110974124A (zh) * | 2019-12-30 | 2020-04-10 | 北京双翼麒电子有限公司 | 内窥镜系统辅助装置 |
| EP4084724A4 (en) | 2019-12-31 | 2023-12-27 | Auris Health, Inc. | ADVANCED BASKET TRAINING MODE |
| EP4084717A4 (en) | 2019-12-31 | 2024-02-14 | Auris Health, Inc. | Dynamic pulley system |
| CN111415564B (zh) * | 2020-03-02 | 2022-03-18 | 武汉大学 | 基于人工智能的胰腺超声内镜检查导航方法及系统 |
| CN111084658B (zh) * | 2020-03-23 | 2020-07-24 | 上海导向医疗系统有限公司 | 冷冻粘连装置 |
| EP4164539A4 (en) * | 2020-06-12 | 2024-06-19 | Digital Surgery Systems, Inc. | System, method, and apparatus for hand-centric controller for the robotic digital surgical microscope |
| CN111603244A (zh) * | 2020-07-03 | 2020-09-01 | 上海市胸科医院 | 一种手术机器人 |
| DE102020130715A1 (de) | 2020-11-20 | 2022-05-25 | Karl Storz SE & Co. KG Intellectual Property | Endoskopische Vorrichtung |
| CN112353496B (zh) * | 2020-11-30 | 2025-04-11 | 沈阳术驰医疗科技有限公司 | 一种软式内窥镜操控机器人 |
| CN114391789B (zh) * | 2021-01-12 | 2025-01-03 | 常州朗合医疗器械有限公司 | 内窥镜手柄及驱动装置 |
| US12527622B2 (en) | 2021-04-26 | 2026-01-20 | Innoblative Designs, Inc. | System for minimally invasive tissue ablation and sealing |
| CN118159178A (zh) * | 2021-11-22 | 2024-06-07 | 奥林巴斯医疗株式会社 | 医疗用机械手系统、医疗用机械手的控制方法及控制装置 |
| CN116919319A (zh) * | 2022-04-08 | 2023-10-24 | 上海澳华内镜股份有限公司 | 内窥镜器械输送装置及医用机器人 |
| CN116616687A (zh) * | 2022-12-12 | 2023-08-22 | 中国人民解放军西部战区总医院 | 一种多功能消化内镜治疗装置 |
Family Cites Families (26)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JPS57190541A (en) | 1981-05-19 | 1982-11-24 | Olympus Optical Co | Endoscope |
| JPS6137938A (ja) | 1984-07-27 | 1986-02-22 | Hitachi Ltd | 分光反射率可変合金及び記録材料 |
| US4854301A (en) * | 1986-11-13 | 1989-08-08 | Olympus Optical Co., Ltd. | Endoscope apparatus having a chair with a switch |
| JPH01270840A (ja) * | 1988-04-25 | 1989-10-30 | Olympus Optical Co Ltd | 内視鏡の挿入補助具 |
| JP2962516B2 (ja) * | 1990-04-20 | 1999-10-12 | オリンパス光学工業株式会社 | 内視鏡装置 |
| US5454378A (en) * | 1993-02-11 | 1995-10-03 | Symbiosis Corporation | Biopsy forceps having a detachable proximal handle and distal jaws |
| US5159446A (en) * | 1991-06-21 | 1992-10-27 | Olympus Optical Co., Ltd. | Electronic endoscope system provided with a separate camera controlling unit and motor controlling unit |
| EP1356781A3 (en) | 1992-01-21 | 2013-07-24 | SRI International | Teleoperation surgical system |
| US5306272A (en) | 1992-11-02 | 1994-04-26 | Neuro Navigational Corporation | Advancer for surgical instrument |
| JP4175693B2 (ja) * | 1998-06-15 | 2008-11-05 | オリンパス株式会社 | 内視鏡用処置具挿抜装置 |
| US6033414A (en) | 1998-06-18 | 2000-03-07 | Cardiac Pacemakers, Inc. | Torque device for left ventricular lead systems |
| JP3549435B2 (ja) * | 1999-03-31 | 2004-08-04 | オリンパス株式会社 | 内視鏡装置 |
| JP4624572B2 (ja) * | 2001-01-30 | 2011-02-02 | オリンパス株式会社 | 内視鏡 |
| JP2003111769A (ja) * | 2001-10-03 | 2003-04-15 | Pentax Corp | 内視鏡用処置具システム |
| US6830545B2 (en) * | 2002-05-13 | 2004-12-14 | Everest Vit | Tube gripper integral with controller for endoscope of borescope |
| SE523297C2 (sv) * | 2002-05-28 | 2004-04-06 | Perific Ab | En anordning för att inmata styrsignaler till en perifer enhet och ett system som inkluderar en sådan anordning |
| US6949104B2 (en) | 2002-05-31 | 2005-09-27 | Jack Griffis | Guide wire steering handle |
| JP4331540B2 (ja) * | 2002-08-06 | 2009-09-16 | オリンパス株式会社 | 内視鏡装置 |
| JP4334838B2 (ja) * | 2002-09-06 | 2009-09-30 | オリンパス株式会社 | 内視鏡装置 |
| JP4657718B2 (ja) * | 2002-09-06 | 2011-03-23 | シー・アール・バード・インク | 内視鏡の外部にある内視鏡付属品制御システム |
| JP4451124B2 (ja) * | 2003-11-28 | 2010-04-14 | オリンパス株式会社 | 内視鏡用処置具挿抜システム |
| DE102004009135B3 (de) * | 2004-02-25 | 2005-12-22 | Siemens Ag | Vorrichtung zur von Hand fernsteuerbaren Navigation einer in einen menschlichen Körper einführbaren Sonde |
| JP2005237659A (ja) * | 2004-02-26 | 2005-09-08 | Olympus Corp | 内視鏡処置システム |
| JP4727158B2 (ja) * | 2004-03-23 | 2011-07-20 | オリンパス株式会社 | 内視鏡システム |
| EP1584300A3 (en) * | 2004-03-30 | 2006-07-05 | Kabushiki Kaisha Toshiba | Manipulator apparatus |
| JP4022526B2 (ja) * | 2004-03-30 | 2007-12-19 | 株式会社東芝 | 医療用器具 |
-
2005
- 2005-11-02 JP JP2005320040A patent/JP5121132B2/ja not_active Expired - Fee Related
-
2006
- 2006-11-02 EP EP06022874A patent/EP1782744B1/en not_active Not-in-force
- 2006-11-02 CN CN200610143193A patent/CN100586362C/zh not_active Expired - Fee Related
- 2006-11-02 US US11/592,094 patent/US7871371B2/en active Active
Also Published As
| Publication number | Publication date |
|---|---|
| US20070100201A1 (en) | 2007-05-03 |
| CN1957836A (zh) | 2007-05-09 |
| EP1782744B1 (en) | 2011-07-06 |
| EP1782744A3 (en) | 2007-08-01 |
| CN100586362C (zh) | 2010-02-03 |
| EP1782744A2 (en) | 2007-05-09 |
| US7871371B2 (en) | 2011-01-18 |
| JP2007125180A (ja) | 2007-05-24 |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| JP2007125180A (ja) | 内視鏡システム、及び内視鏡用操作補助装置 | |
| JP5203002B2 (ja) | 内視鏡用操作補助装置 | |
| JP4624572B2 (ja) | 内視鏡 | |
| JP4755243B2 (ja) | 内視鏡システム、及び医療器具 | |
| JP4763420B2 (ja) | 内視鏡用操作補助装置 | |
| JP4728075B2 (ja) | 内視鏡システム | |
| JP5364868B1 (ja) | 内視鏡 | |
| US8075475B2 (en) | Endoscope system and medical instrument | |
| EP2471472B1 (en) | Intra-abdominal cavity operation supporting forceps and medical procedure using intra-abdominal cavity operation supporting forceps | |
| JP4914891B2 (ja) | 内視鏡処置システム | |
| EP3967210A1 (en) | Endoscope | |
| JP5096202B2 (ja) | 内視鏡システム | |
| JP4424767B2 (ja) | 喉頭手術装置 | |
| JP2006149880A (ja) | 内視鏡の操作部 | |
| KR101764720B1 (ko) | 내시경 시술기구 | |
| JP2005168820A (ja) | 内視鏡保持装置 | |
| WO2014156243A1 (ja) | 軟性医療機器保持装置 | |
| JP2012050554A (ja) | 内視鏡操作部の連結機構 | |
| WO2017018139A1 (ja) | 内視鏡用外科手術装置及び案内装置 |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| A621 | Written request for application examination |
Free format text: JAPANESE INTERMEDIATE CODE: A621 Effective date: 20080924 |
|
| A977 | Report on retrieval |
Free format text: JAPANESE INTERMEDIATE CODE: A971007 Effective date: 20110418 |
|
| A131 | Notification of reasons for refusal |
Free format text: JAPANESE INTERMEDIATE CODE: A131 Effective date: 20110426 |
|
| A521 | Request for written amendment filed |
Free format text: JAPANESE INTERMEDIATE CODE: A523 Effective date: 20110627 |
|
| A131 | Notification of reasons for refusal |
Free format text: JAPANESE INTERMEDIATE CODE: A131 Effective date: 20120821 |
|
| A521 | Request for written amendment filed |
Free format text: JAPANESE INTERMEDIATE CODE: A523 Effective date: 20120924 |
|
| TRDD | Decision of grant or rejection written | ||
| A01 | Written decision to grant a patent or to grant a registration (utility model) |
Free format text: JAPANESE INTERMEDIATE CODE: A01 Effective date: 20121016 |
|
| A01 | Written decision to grant a patent or to grant a registration (utility model) |
Free format text: JAPANESE INTERMEDIATE CODE: A01 |
|
| A61 | First payment of annual fees (during grant procedure) |
Free format text: JAPANESE INTERMEDIATE CODE: A61 Effective date: 20121023 |
|
| FPAY | Renewal fee payment (event date is renewal date of database) |
Free format text: PAYMENT UNTIL: 20151102 Year of fee payment: 3 |
|
| R151 | Written notification of patent or utility model registration |
Ref document number: 5121132 Country of ref document: JP Free format text: JAPANESE INTERMEDIATE CODE: R151 |
|
| FPAY | Renewal fee payment (event date is renewal date of database) |
Free format text: PAYMENT UNTIL: 20151102 Year of fee payment: 3 |
|
| S111 | Request for change of ownership or part of ownership |
Free format text: JAPANESE INTERMEDIATE CODE: R313111 |
|
| R350 | Written notification of registration of transfer |
Free format text: JAPANESE INTERMEDIATE CODE: R350 |
|
| S531 | Written request for registration of change of domicile |
Free format text: JAPANESE INTERMEDIATE CODE: R313531 |
|
| R350 | Written notification of registration of transfer |
Free format text: JAPANESE INTERMEDIATE CODE: R350 |
|
| R250 | Receipt of annual fees |
Free format text: JAPANESE INTERMEDIATE CODE: R250 |
|
| R250 | Receipt of annual fees |
Free format text: JAPANESE INTERMEDIATE CODE: R250 |
|
| R250 | Receipt of annual fees |
Free format text: JAPANESE INTERMEDIATE CODE: R250 |
|
| R250 | Receipt of annual fees |
Free format text: JAPANESE INTERMEDIATE CODE: R250 |
|
| LAPS | Cancellation because of no payment of annual fees |