JP5128904B2 - マニピュレータ - Google Patents
マニピュレータ Download PDFInfo
- Publication number
- JP5128904B2 JP5128904B2 JP2007283323A JP2007283323A JP5128904B2 JP 5128904 B2 JP5128904 B2 JP 5128904B2 JP 2007283323 A JP2007283323 A JP 2007283323A JP 2007283323 A JP2007283323 A JP 2007283323A JP 5128904 B2 JP5128904 B2 JP 5128904B2
- Authority
- JP
- Japan
- Prior art keywords
- end effector
- passive
- manipulator
- cylinder
- wire
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Active
Links
Images







Classifications
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B25—HAND TOOLS; PORTABLE POWER-DRIVEN TOOLS; MANIPULATORS
- B25J—MANIPULATORS; CHAMBERS PROVIDED WITH MANIPULATION DEVICES
- B25J9/00—Program-controlled manipulators
- B25J9/10—Program-controlled manipulators characterised by positioning means for manipulator elements
- B25J9/104—Program-controlled manipulators characterised by positioning means for manipulator elements with cables, chains or ribbons
-
- A—HUMAN NECESSITIES
- A61—MEDICAL OR VETERINARY SCIENCE; HYGIENE
- A61B—DIAGNOSIS; SURGERY; IDENTIFICATION
- A61B34/00—Computer-aided surgery; Manipulators or robots specially adapted for use in surgery
- A61B34/70—Manipulators specially adapted for use in surgery
-
- A—HUMAN NECESSITIES
- A61—MEDICAL OR VETERINARY SCIENCE; HYGIENE
- A61B—DIAGNOSIS; SURGERY; IDENTIFICATION
- A61B34/00—Computer-aided surgery; Manipulators or robots specially adapted for use in surgery
- A61B34/70—Manipulators specially adapted for use in surgery
- A61B34/71—Manipulators operated by drive cable mechanisms
-
- A—HUMAN NECESSITIES
- A61—MEDICAL OR VETERINARY SCIENCE; HYGIENE
- A61B—DIAGNOSIS; SURGERY; IDENTIFICATION
- A61B18/00—Surgical instruments, devices or methods for transferring non-mechanical forms of energy to or from the body
- A61B18/04—Surgical instruments, devices or methods for transferring non-mechanical forms of energy to or from the body by heating
- A61B18/12—Surgical instruments, devices or methods for transferring non-mechanical forms of energy to or from the body by heating by passing a current through the tissue to be heated, e.g. high-frequency current
- A61B18/14—Probes or electrodes therefor
- A61B18/1442—Probes having pivoting end effectors, e.g. forceps
- A61B18/1445—Probes having pivoting end effectors, e.g. forceps at the distal end of a shaft, e.g. forceps or scissors at the end of a rigid rod
-
- A—HUMAN NECESSITIES
- A61—MEDICAL OR VETERINARY SCIENCE; HYGIENE
- A61B—DIAGNOSIS; SURGERY; IDENTIFICATION
- A61B17/00—Surgical instruments, devices or methods
- A61B17/28—Surgical forceps
- A61B17/29—Forceps for use in minimally invasive surgery
- A61B2017/2926—Details of heads or jaws
- A61B2017/2927—Details of heads or jaws the angular position of the head being adjustable with respect to the shaft
-
- A—HUMAN NECESSITIES
- A61—MEDICAL OR VETERINARY SCIENCE; HYGIENE
- A61B—DIAGNOSIS; SURGERY; IDENTIFICATION
- A61B17/00—Surgical instruments, devices or methods
- A61B17/28—Surgical forceps
- A61B17/29—Forceps for use in minimally invasive surgery
- A61B2017/2926—Details of heads or jaws
- A61B2017/2932—Transmission of forces to jaw members
-
- A—HUMAN NECESSITIES
- A61—MEDICAL OR VETERINARY SCIENCE; HYGIENE
- A61B—DIAGNOSIS; SURGERY; IDENTIFICATION
- A61B17/00—Surgical instruments, devices or methods
- A61B17/28—Surgical forceps
- A61B17/29—Forceps for use in minimally invasive surgery
- A61B2017/2926—Details of heads or jaws
- A61B2017/2932—Transmission of forces to jaw members
- A61B2017/2939—Details of linkages or pivot points
-
- A—HUMAN NECESSITIES
- A61—MEDICAL OR VETERINARY SCIENCE; HYGIENE
- A61B—DIAGNOSIS; SURGERY; IDENTIFICATION
- A61B34/00—Computer-aided surgery; Manipulators or robots specially adapted for use in surgery
- A61B34/70—Manipulators specially adapted for use in surgery
- A61B34/74—Manipulators with manual electric input means
- A61B2034/742—Joysticks
Landscapes
- Engineering & Computer Science (AREA)
- Health & Medical Sciences (AREA)
- Surgery (AREA)
- Life Sciences & Earth Sciences (AREA)
- Robotics (AREA)
- Heart & Thoracic Surgery (AREA)
- Nuclear Medicine, Radiotherapy & Molecular Imaging (AREA)
- Biomedical Technology (AREA)
- Medical Informatics (AREA)
- Molecular Biology (AREA)
- Animal Behavior & Ethology (AREA)
- General Health & Medical Sciences (AREA)
- Public Health (AREA)
- Veterinary Medicine (AREA)
- Mechanical Engineering (AREA)
- Manipulator (AREA)
- Surgical Instruments (AREA)
- Transmission Devices (AREA)
Description
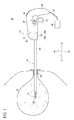
14…操作部 16…作業部
32…トリガレバー 40、41、42…モータ
48…連結シャフト 52、54、56…ワイヤ
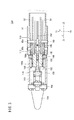
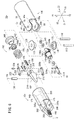
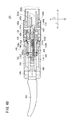
104、300…エンドエフェクタ
140、140a、140b…アイドルプーリ
142、142a、142b…ガイドプーリ
150…スプリング 152…ロッド
156、156a、156b…受動プーリ
158…受動板 160…カバー
202、212、302…グリッパ
252、252a、252b…受動ワイヤ
260、320a、320b、340a、340b…エンドエフェクタ駆動機構
322…駆動側連結 ワイヤ324…駆動側連結プーリ
326a、326b…駆動リンク 328…受動側連結ワイヤ
330…受動側連結プーリ 350…折り返しプーリ
Claims (25)
- 先端のエンドエフェクタを含み、関節部を介して揺動可能な先端動作部と、
基端側から前記エンドエフェクタへと駆動力を伝達するエンドエフェクタ駆動機構と、
を備えるマニピュレータであって、
前記エンドエフェクタ駆動機構は、
基端側に設けられ、進退する駆動部材と、
前記駆動部材に一部が接続された環状の可撓性部材と、
前記駆動部材より先端側で且つ前記関節部より基端側に設けられたアイドル円柱体と、
前記先端動作部に、当該先端動作部の延在方向に進退可能に設けられた受動円柱体と、
前記アイドル円柱体と前記受動円柱体との間にある前記関節部に設けられたガイド円柱体と、
前記受動円柱体の進退動作に連動して、開閉動作する前記エンドエフェクタと、
を含み、
前記可撓性部材は、前記アイドル円柱体の両側方を通り、前記受動円柱体に巻き掛けられ、前記アイドル円柱体と前記ガイド円柱体との間で交差していることを特徴とするマニピュレータ。 - 請求項1記載のマニピュレータにおいて、
前記アイドル円柱体と前記ガイド円柱体における前記可撓性部材が巻きかけられる箇所の隙間は、前記可撓性部材の太さの1倍〜2倍であることを特徴とするマニピュレータ。 - 請求項1又は2記載のマニピュレータにおいて、
前記アイドル円柱体は、同軸上の第1層アイドル円柱体と第2層アイドル円柱体の2枚が並列して構成されることを特徴とするマニピュレータ。 - 先端のエンドエフェクタを含み、関節部を介して揺動可能な先端動作部と、
基端側から前記エンドエフェクタへと駆動力を伝達するエンドエフェクタ駆動機構と、
を備えるマニピュレータであって、
前記エンドエフェクタ駆動機構は、
基端側に設けられ、進退する駆動部材と、
前記駆動部材に一部が接続された環状の可撓性部材と、
前記駆動部材より先端側で前記関節部に設けられたガイド円柱体と、
前記ガイド円柱体より先端側で、前記先端動作部に、当該先端動作部の延在方向に進退可能に設けられた受動円柱体と、
前記受動円柱体の進退動作に連動して、開閉動作する前記エンドエフェクタと、
を含み、
前記可撓性部材は、前記ガイド円柱体に、少なくとも一方からそれぞれ1巻き以上巻き掛けられるとともに、前記受動円柱体に巻き掛けられていることを特徴とするマニピュレータ。 - 請求項1〜4のいずれか1項に記載のマニピュレータにおいて、
前記受動円柱体よりも先端側に折り返し円柱体を有し、
前記可撓性部材は、前記受動円柱体と前記折り返し円柱体とにわたって巻き掛けられていることを特徴とするマニピュレータ。 - 請求項1〜5のいずれか1項に記載のマニピュレータにおいて、
前記受動円柱体を一方向に付勢する弾性体を有することを特徴とするマニピュレータ。 - 請求項1〜6のいずれか1項に記載のマニピュレータにおいて、
前記ガイド円柱体を基準として前記エンドエフェクタを揺動させる揺動機構を有することを特徴とするマニピュレータ。 - 請求項1〜7のいずれか1項に記載のマニピュレータにおいて、
前記ガイド円柱体は、同軸上の第1層ガイド円柱体と第2層ガイド円柱体の2枚が並列して構成されることを特徴とするマニピュレータ。 - 請求項1〜8のいずれか1項に記載のマニピュレータにおいて、
前記駆動部材には基端側を指向する円弧壁が設けられ、該円弧壁に前記可撓性部材が掛けられていることを特徴とするマニピュレータ。 - 請求項1〜8のいずれか1項に記載のマニピュレータにおいて、
前記駆動部材にはローラが設けられ、該ローラに前記可撓性部材が巻き掛けられていることを特徴とするマニピュレータ。 - 請求項1〜10のいずれか1項に記載のマニピュレータにおいて、
前記可撓性部材は1本の線材からなり、前記駆動部材に対する接続部以外の箇所で、両端が固定されることにより環状となっていることを特徴とするマニピュレータ。 - 請求項1〜11のいずれか1項に記載のマニピュレータにおいて、
前記エンドエフェクタ駆動機構は、第1エンドエフェクタ駆動機構及び第2エンドエフェクタ駆動機構の2セットが設けられ、
前記第1エンドエフェクタ駆動機構の前記駆動部材と前記第2エンドエフェクタ駆動機構の前記駆動部材を逆方向に進退させる駆動部材進退機構を有することを特徴とするマニピュレータ。 - 請求項12記載のマニピュレータにおいて、
前記第1エンドエフェクタ駆動機構及び前記第2エンドエフェクタ駆動機構のいずれか一方で、
前記受動円柱体よりも先端側に折り返し円柱体を有し、
前記可撓性部材は、前記受動円柱体と前記折り返し円柱体とにわたって巻き掛けられていることを特徴とするマニピュレータ。 - 請求項13記載のマニピュレータにおいて、
前記第1エンドエフェクタ駆動機構の前記受動円柱体と、前記第2エンドエフェクタ駆動機構の前記受動円柱体は、同軸上に配置されていることを特徴とするマニピュレータ。 - 請求項12〜14のいずれか1項に記載のマニピュレータにおいて、
前記第1エンドエフェクタ駆動機構の前記ガイド円柱体と、前記第2エンドエフェクタ駆動機構の前記ガイド円柱体は、同軸上に配置されていることを特徴とするマニピュレータ。 - 請求項15に記載のマニピュレータにおいて、
2つの前記ガイド円柱体は、それぞれ同軸上で外寄りの第1層ガイド円柱体と内寄りの第2層ガイド円柱体の2枚が並列して構成され、内寄りの2つの前記第2層ガイド円柱体は一体構成であることを特徴とするマニピュレータ。 - 請求項12〜16のいずれか1項に記載のマニピュレータにおいて、
前記駆動部材進退機構は、支点を基準として回転する回転操作子を有し、
前記第1エンドエフェクタ駆動機構の前記駆動部材は前記回転操作子の前記支点を基準とした一方に接続され、前記第2エンドエフェクタ駆動機構の前記駆動部材は前記回転操作子の前記支点を基準とした他方に接続されていることを特徴とするマニピュレータ。 - 請求項17記載のマニピュレータにおいて、
2つの前記駆動部材は駆動側連結可撓性部材で接続され、
前記回転操作子は、円柱体であって、前記駆動側連結可撓性部材が巻き掛けられていることを特徴とするマニピュレータ。 - 請求項18記載のマニピュレータにおいて、
前記駆動側連結可撓性部材に当接し、該駆動側連結可撓性部材の配置経路を規定するアイドラーを有することを特徴とするマニピュレータ。 - 請求項12、15〜19のいずれか1項に記載のマニピュレータにおいて、
一端が前記第1エンドエフェクタ駆動機構の前記受動円柱体に接続され、他端が前記第2エンドエフェクタ駆動機構の前記受動円柱体に接続された受動側連結可撓性部材と、
前記受動側連結可撓性部材が巻き掛けられた受動側連結円柱体と、
を有することを特徴とするマニピュレータ。 - 請求項1〜20のいずれか1項に記載のマニピュレータにおいて、
前記駆動部材は、人手によって操作する入力部に対して機械的に接続されていることを特徴とするマニピュレータ。 - 請求項1〜20のいずれか1項に記載のマニピュレータにおいて、
人手によって操作する入力部に連動するアクチュエータを有し、
前記駆動部材は、前記アクチュエータに接続されていることを特徴とするマニピュレータ。 - 請求項1〜22のいずれか1項に記載のマニピュレータにおいて、
前記可撓性部材は、前記駆動部材よりも細径であることを特徴とするマニピュレータ。 - 請求項1〜23のいずれか1項に記載のマニピュレータにおいて、
前記駆動部材は、ワイヤであることを特徴とするマニピュレータ。 - 請求項1〜24のいずれか1項に記載のマニピュレータにおいて、
前記受動円柱体及び前記ガイド円柱体は、プーリであることを特徴とするマニピュレータ。
Priority Applications (3)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| JP2007283323A JP5128904B2 (ja) | 2007-10-31 | 2007-10-31 | マニピュレータ |
| EP08167957.3A EP2077095B1 (en) | 2007-10-31 | 2008-10-30 | Manipulator actuated by wires and pulleys |
| US12/261,829 US8277443B2 (en) | 2007-10-31 | 2008-10-30 | Manipulator |
Applications Claiming Priority (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| JP2007283323A JP5128904B2 (ja) | 2007-10-31 | 2007-10-31 | マニピュレータ |
Publications (2)
| Publication Number | Publication Date |
|---|---|
| JP2009107087A JP2009107087A (ja) | 2009-05-21 |
| JP5128904B2 true JP5128904B2 (ja) | 2013-01-23 |
Family
ID=40583814
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| JP2007283323A Active JP5128904B2 (ja) | 2007-10-31 | 2007-10-31 | マニピュレータ |
Country Status (3)
| Country | Link |
|---|---|
| US (1) | US8277443B2 (ja) |
| EP (1) | EP2077095B1 (ja) |
| JP (1) | JP5128904B2 (ja) |
Cited By (1)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JP3000415B2 (ja) | 1993-10-04 | 2000-01-17 | 三立技研工業株式会社 | 移動式作業台 |
Families Citing this family (76)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| KR100911248B1 (ko) * | 2007-10-17 | 2009-08-07 | 국립암센터 | 소구경 복강경 수술기구 |
| JP5364255B2 (ja) * | 2007-10-31 | 2013-12-11 | テルモ株式会社 | 医療用マニピュレータ |
| JP2009201607A (ja) * | 2008-02-26 | 2009-09-10 | Terumo Corp | マニピュレータ |
| US8332072B1 (en) | 2008-08-22 | 2012-12-11 | Titan Medical Inc. | Robotic hand controller |
| US10532466B2 (en) * | 2008-08-22 | 2020-01-14 | Titan Medical Inc. | Robotic hand controller |
| US8523900B2 (en) * | 2009-02-03 | 2013-09-03 | Terumo Kabushiki Kaisha | Medical manipulator |
| JP5320093B2 (ja) * | 2009-02-03 | 2013-10-23 | テルモ株式会社 | 医療用マニピュレータ |
| JP5320121B2 (ja) * | 2009-03-27 | 2013-10-23 | テルモ株式会社 | 医療用マニピュレータ |
| JP5593654B2 (ja) * | 2009-08-31 | 2014-09-24 | 日本精工株式会社 | ロボット関節部 |
| WO2011033881A1 (ja) * | 2009-09-15 | 2011-03-24 | オリンパスメディカルシステムズ株式会社 | 高周波処置具 |
| US9474540B2 (en) | 2009-10-08 | 2016-10-25 | Ethicon-Endo-Surgery, Inc. | Laparoscopic device with compound angulation |
| US8074859B2 (en) * | 2010-03-31 | 2011-12-13 | Tyco Healthcare Group Lp | Surgical instrument |
| US20110257680A1 (en) * | 2010-04-20 | 2011-10-20 | Tyco Healthcare Group Lp | Surgical Forceps Including Pulley Blade Reverser Mechanism |
| US8562592B2 (en) | 2010-05-07 | 2013-10-22 | Ethicon Endo-Surgery, Inc. | Compound angle laparoscopic methods and devices |
| US20110275901A1 (en) * | 2010-05-07 | 2011-11-10 | Ethicon Endo-Surgery, Inc. | Laparoscopic devices with articulating end effectors |
| US9226760B2 (en) | 2010-05-07 | 2016-01-05 | Ethicon Endo-Surgery, Inc. | Laparoscopic devices with flexible actuation mechanisms |
| US9198729B2 (en) * | 2010-11-15 | 2015-12-01 | Intuitive Surgical Operations, Inc. | Actuation cable having multiple friction characteristics |
| US8480703B2 (en) * | 2010-11-19 | 2013-07-09 | Covidien Lp | Surgical device |
| WO2012073789A1 (ja) * | 2010-11-30 | 2012-06-07 | オリンパス株式会社 | マスタ操作入力装置及びマスタスレーブマニピュレータ |
| DE102011011497A1 (de) * | 2011-02-17 | 2012-08-23 | Kuka Roboter Gmbh | Chirurgisches Instrument |
| JP5856817B2 (ja) * | 2011-11-16 | 2016-02-10 | オリンパス株式会社 | 医療用処置具およびこれを備えるマニピュレータ |
| KR101427330B1 (ko) * | 2011-11-23 | 2014-08-06 | 주식회사 리브스메드 | 차동 부재 |
| WO2013077571A1 (ko) | 2011-11-23 | 2013-05-30 | 주식회사 리브스메드 | 수술용 인스트루먼트 |
| US9364220B2 (en) | 2012-06-19 | 2016-06-14 | Covidien Lp | Apparatus for endoscopic procedures |
| JP6042652B2 (ja) * | 2012-07-30 | 2016-12-14 | オリンパス株式会社 | 術具及び医療用マニピュレータ |
| BR112015006554B1 (pt) | 2012-09-26 | 2023-01-17 | Aesculap Ag | Dispositivo eletro cirúrgico para corte e selagem de tecidos |
| EP2914197B1 (en) | 2012-11-02 | 2020-12-09 | Intuitive Surgical Operations, Inc. | Self-antagonistic drive for medical instruments |
| WO2014123246A1 (en) * | 2013-02-08 | 2014-08-14 | Olympus Corp. | Manipulator |
| CN105026116B (zh) * | 2013-02-27 | 2017-03-08 | 奥林巴斯株式会社 | 机械手 |
| JP6188787B2 (ja) * | 2013-03-18 | 2017-08-30 | オリンパス株式会社 | マニピュレータ |
| US10076348B2 (en) * | 2013-08-15 | 2018-09-18 | Intuitive Surgical Operations, Inc. | Rotary input for lever actuation |
| JP6049585B2 (ja) * | 2013-10-31 | 2016-12-21 | オリンパス株式会社 | 術具 |
| JP5980764B2 (ja) * | 2013-11-29 | 2016-08-31 | オリンパス株式会社 | 術具 |
| JP6230430B2 (ja) * | 2014-01-23 | 2017-11-15 | オリンパス株式会社 | 術具及び医療用マニピュレータシステム |
| KR101584766B1 (ko) | 2014-04-24 | 2016-01-12 | 주식회사 리브스메드 | 수술용 인스트루먼트 |
| JP6701172B2 (ja) | 2014-08-13 | 2020-05-27 | コヴィディエン リミテッド パートナーシップ | 機械的利益把握のロボット制御 |
| AU2015302216B2 (en) | 2014-08-13 | 2019-09-26 | Covidien Lp | Robotically controlling mechanical advantage gripping |
| US9469027B2 (en) * | 2014-08-25 | 2016-10-18 | Paul Ekas | Tendon based robotic fingers having shock absorbing and self re-aligning features |
| CN104188709B (zh) * | 2014-09-18 | 2016-07-06 | 上海工程技术大学 | 一种用于外科手术机器人的多角度从手镊子 |
| WO2016052784A1 (ko) | 2014-10-02 | 2016-04-07 | 주식회사 리브스메드 | 수술용 인스트루먼트 |
| US11896336B2 (en) | 2015-02-17 | 2024-02-13 | Livsmed Inc. | Instrument for surgery |
| US11344381B2 (en) | 2015-02-17 | 2022-05-31 | Livsmed Inc. | Instrument for surgery |
| KR102153407B1 (ko) | 2015-02-17 | 2020-09-08 | 주식회사 리브스메드 | 수술용 인스트루먼트 |
| EP3263053A4 (en) * | 2015-02-26 | 2018-11-07 | Olympus Corporation | Medical treatment instrument |
| WO2016194067A1 (ja) | 2015-05-29 | 2016-12-08 | オリンパス株式会社 | 把持機構および把持具 |
| WO2016209788A1 (en) | 2015-06-23 | 2016-12-29 | Covidien Lp | Surgical end effectors with mechanical advantage |
| US20170014135A1 (en) * | 2015-07-14 | 2017-01-19 | Keith Edward Martin | Surgical tool |
| CN107249831B (zh) * | 2015-07-17 | 2020-06-30 | 奥林巴斯株式会社 | 机械手 |
| NL2015423B1 (en) * | 2015-09-10 | 2017-03-29 | Deam Holding B V | Surgical instrument. |
| ITUB20155057A1 (it) | 2015-10-16 | 2017-04-16 | Medical Microinstruments S R L | Assieme robotico di chirurgia |
| ITUB20154977A1 (it) | 2015-10-16 | 2017-04-16 | Medical Microinstruments S R L | Strumento medicale e metodo di fabbricazione di detto strumento medicale |
| US12390287B2 (en) | 2015-10-16 | 2025-08-19 | Medical Microinstruments, Inc. | Surgical tool for robotic surgery and robotic surgical assembly |
| CN109219412B (zh) * | 2016-03-07 | 2022-02-08 | 伊西康有限责任公司 | 机器人双极器械 |
| WO2017195246A1 (ja) | 2016-05-09 | 2017-11-16 | オリンパス株式会社 | 把持機構および把持具 |
| WO2017212587A1 (ja) * | 2016-06-08 | 2017-12-14 | オリンパス株式会社 | 把持機構および把持具 |
| WO2018013298A1 (en) | 2016-07-14 | 2018-01-18 | Intuitive Surgical Operations, Inc. | Geared grip actuation for medical instruments |
| US11160625B2 (en) | 2016-10-14 | 2021-11-02 | Intuitive Surgical Operations, Inc. | Systems to apply preload tension for surgical instruments and related methods |
| WO2018096689A1 (ja) | 2016-11-28 | 2018-05-31 | オリンパス株式会社 | 医療用処置具 |
| IT201700041980A1 (it) | 2017-04-14 | 2018-10-14 | Medical Microinstruments Spa | Assieme robotico per microchirurgia |
| NL2019146B1 (en) | 2017-06-29 | 2019-01-14 | Deam Holding B V | Medical device with flexible tip |
| US10973600B2 (en) * | 2017-09-29 | 2021-04-13 | Ethicon Llc | Power axle wrist for robotic surgical tool |
| KR102191482B1 (ko) | 2017-11-14 | 2020-12-15 | 주식회사 리브스메드 | 수술용 인스트루먼트의 롤 조인트 부재 |
| CN108969026B (zh) * | 2018-05-25 | 2019-06-25 | 安瑞医疗器械(杭州)有限公司 | 一种医用钳子 |
| JP2019217025A (ja) * | 2018-06-20 | 2019-12-26 | リバーフィールド株式会社 | 術具 |
| SE542910C2 (en) * | 2018-12-14 | 2020-09-15 | Multi4 Ab | An endosurgical device |
| CN111374716B (zh) * | 2018-12-29 | 2024-12-20 | 达科为(深圳)医疗设备有限公司 | 一种手术刀组件及其安装座 |
| CN114786598B (zh) * | 2019-12-25 | 2023-04-25 | 瑞德医疗机器股份有限公司 | 手术器具 |
| CN114828760B (zh) * | 2019-12-25 | 2023-04-04 | 瑞德医疗机器股份有限公司 | 手术器具 |
| CN115315224B (zh) * | 2020-03-27 | 2024-03-08 | 瑞德医疗机器股份有限公司 | 手术工具 |
| EP3967243B1 (en) * | 2020-09-15 | 2024-01-17 | Beijing Longmiao Medical Device Co., Ltd. | Biopsy forceps and jaw assembly thereof |
| JP7499677B2 (ja) * | 2020-10-29 | 2024-06-14 | 川崎重工業株式会社 | ロボットハンド |
| JP2023554516A (ja) | 2020-12-22 | 2023-12-27 | メディカル・マイクロインストゥルメンツ・インコーポレイテッド | ロボット手術用の外科器具及びロボット手術アセンブリ |
| CN112847424B (zh) * | 2020-12-24 | 2022-04-19 | 中国科学技术大学 | 一种刚度放大绳驱动单自由度关节 |
| US20220226058A1 (en) * | 2021-01-21 | 2022-07-21 | Ethicon Llc | Robotic surgical instruments with drive belt shaft insertion |
| TWI836752B (zh) * | 2021-11-30 | 2024-03-21 | 美商安督奎斯特機器人公司 | 用於機器人控制醫療裝置的力傳輸系統 |
| CN114305592B (zh) * | 2022-01-07 | 2023-06-23 | 苏州康多机器人有限公司 | 一种偏摆机构及手术器械 |
Family Cites Families (24)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JPS63176092U (ja) * | 1986-10-21 | 1988-11-15 | ||
| US4782833A (en) | 1987-02-19 | 1988-11-08 | Thomas A. Einhorn | Bone boring instrument |
| JPS63288147A (ja) * | 1987-05-21 | 1988-11-25 | Olympus Optical Co Ltd | クリップ装置 |
| DE4136861C2 (de) | 1991-11-11 | 1994-12-15 | Kernforschungsz Karlsruhe | Steuerbares chirurgisches Instrument |
| US5792165A (en) | 1993-07-21 | 1998-08-11 | Charles H. Klieman | Endoscopic instrument with detachable end effector |
| US5507773A (en) * | 1994-02-18 | 1996-04-16 | Ethicon Endo-Surgery | Cable-actuated jaw assembly for surgical instruments |
| DE69532486T2 (de) | 1994-03-17 | 2004-12-23 | Terumo K.K. | Chirurgisches Instrument |
| US5828813A (en) * | 1995-09-07 | 1998-10-27 | California Institute Of Technology | Six axis force feedback input device |
| US5797900A (en) * | 1996-05-20 | 1998-08-25 | Intuitive Surgical, Inc. | Wrist mechanism for surgical instrument for performing minimally invasive surgery with enhanced dexterity and sensitivity |
| JP3126323B2 (ja) * | 1996-11-01 | 2001-01-22 | 株式会社貝印刃物開発センター | 内視鏡用処置具における処置部の構造 |
| US5899914A (en) | 1997-06-11 | 1999-05-04 | Endius Incorporated | Surgical instrument |
| US20020095175A1 (en) * | 1998-02-24 | 2002-07-18 | Brock David L. | Flexible instrument |
| JP4014792B2 (ja) | 2000-09-29 | 2007-11-28 | 株式会社東芝 | マニピュレータ |
| US20030135204A1 (en) * | 2001-02-15 | 2003-07-17 | Endo Via Medical, Inc. | Robotically controlled medical instrument with a flexible section |
| JP2002282257A (ja) * | 2001-03-26 | 2002-10-02 | Medicraft:Kk | 医療用持針器 |
| US6817974B2 (en) | 2001-06-29 | 2004-11-16 | Intuitive Surgical, Inc. | Surgical tool having positively positionable tendon-actuated multi-disk wrist joint |
| JP3631450B2 (ja) * | 2001-08-22 | 2005-03-23 | 株式会社東芝 | マニピュレータ |
| JP4050032B2 (ja) * | 2001-10-09 | 2008-02-20 | オリンパス株式会社 | 内視鏡用処置具の操作装置 |
| JP3912251B2 (ja) * | 2002-10-02 | 2007-05-09 | 株式会社日立製作所 | マニピュレータ |
| JP3944108B2 (ja) * | 2003-03-31 | 2007-07-11 | 株式会社東芝 | 医療用マニピュレータの動力伝達機構およびマニピュレータ |
| JP4512194B2 (ja) * | 2005-03-14 | 2010-07-28 | 株式会社日立製作所 | ロボットアーム |
| EP1707153B1 (en) | 2005-03-29 | 2012-02-01 | Kabushiki Kaisha Toshiba | Manipulator |
| US20070208375A1 (en) * | 2006-02-23 | 2007-09-06 | Kouji Nishizawa | Surgical device |
| JP5364255B2 (ja) | 2007-10-31 | 2013-12-11 | テルモ株式会社 | 医療用マニピュレータ |
-
2007
- 2007-10-31 JP JP2007283323A patent/JP5128904B2/ja active Active
-
2008
- 2008-10-30 US US12/261,829 patent/US8277443B2/en active Active
- 2008-10-30 EP EP08167957.3A patent/EP2077095B1/en active Active
Cited By (1)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JP3000415B2 (ja) | 1993-10-04 | 2000-01-17 | 三立技研工業株式会社 | 移動式作業台 |
Also Published As
| Publication number | Publication date |
|---|---|
| EP2077095A3 (en) | 2018-07-11 |
| EP2077095B1 (en) | 2019-08-21 |
| EP2077095A2 (en) | 2009-07-08 |
| US8277443B2 (en) | 2012-10-02 |
| JP2009107087A (ja) | 2009-05-21 |
| US20090112230A1 (en) | 2009-04-30 |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| JP2009107087A (ja) | マニピュレータ | |
| JP5364255B2 (ja) | 医療用マニピュレータ | |
| US8523900B2 (en) | Medical manipulator | |
| JP5323578B2 (ja) | 医療用ロボットシステム | |
| JP5320121B2 (ja) | 医療用マニピュレータ | |
| JP3912251B2 (ja) | マニピュレータ | |
| JP5875973B2 (ja) | 医療用マニピュレータ | |
| JP5431749B2 (ja) | 医療用マニピュレータ | |
| JP5400444B2 (ja) | 医療用器具の製造方法及び医療用器具 | |
| JP2011072574A (ja) | 医療用マニピュレータ | |
| US6991627B2 (en) | Articulated surgical instrument for performing minimally invasive surgery with enhanced dexterity and sensitivity | |
| CN107809981A (zh) | 用于致动元件的张力调节器,以及相关远程致动器械、系统和方法 | |
| US11660150B2 (en) | Dexterous 4-DOF surgical tool for compact articulation | |
| JP2009201607A (ja) | マニピュレータ | |
| JP5320093B2 (ja) | 医療用マニピュレータ | |
| WO2011040369A1 (ja) | 医療用マニピュレータ | |
| JP2010227555A (ja) | 医療用マニピュレータ | |
| US20240415591A1 (en) | Force transmission systems using planetary gear assembly, and related devices and methods | |
| JP2010253205A (ja) | マニピュレータ |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| A621 | Written request for application examination |
Free format text: JAPANESE INTERMEDIATE CODE: A621 Effective date: 20100917 |
|
| A977 | Report on retrieval |
Free format text: JAPANESE INTERMEDIATE CODE: A971007 Effective date: 20120413 |
|
| A131 | Notification of reasons for refusal |
Free format text: JAPANESE INTERMEDIATE CODE: A131 Effective date: 20120424 |
|
| A521 | Request for written amendment filed |
Free format text: JAPANESE INTERMEDIATE CODE: A523 Effective date: 20120622 |
|
| TRDD | Decision of grant or rejection written | ||
| A01 | Written decision to grant a patent or to grant a registration (utility model) |
Free format text: JAPANESE INTERMEDIATE CODE: A01 Effective date: 20121016 |
|
| A01 | Written decision to grant a patent or to grant a registration (utility model) |
Free format text: JAPANESE INTERMEDIATE CODE: A01 |
|
| A61 | First payment of annual fees (during grant procedure) |
Free format text: JAPANESE INTERMEDIATE CODE: A61 Effective date: 20121101 |
|
| R150 | Certificate of patent or registration of utility model |
Ref document number: 5128904 Country of ref document: JP Free format text: JAPANESE INTERMEDIATE CODE: R150 Free format text: JAPANESE INTERMEDIATE CODE: R150 |
|
| FPAY | Renewal fee payment (event date is renewal date of database) |
Free format text: PAYMENT UNTIL: 20151109 Year of fee payment: 3 |
|
| S111 | Request for change of ownership or part of ownership |
Free format text: JAPANESE INTERMEDIATE CODE: R313113 |
|
| R350 | Written notification of registration of transfer |
Free format text: JAPANESE INTERMEDIATE CODE: R350 |
|
| R250 | Receipt of annual fees |
Free format text: JAPANESE INTERMEDIATE CODE: R250 |
|
| R250 | Receipt of annual fees |
Free format text: JAPANESE INTERMEDIATE CODE: R250 |
|
| R250 | Receipt of annual fees |
Free format text: JAPANESE INTERMEDIATE CODE: R250 |
|
| S531 | Written request for registration of change of domicile |
Free format text: JAPANESE INTERMEDIATE CODE: R313531 |
|
| S533 | Written request for registration of change of name |
Free format text: JAPANESE INTERMEDIATE CODE: R313533 |
|
| R350 | Written notification of registration of transfer |
Free format text: JAPANESE INTERMEDIATE CODE: R350 |
|
| R250 | Receipt of annual fees |
Free format text: JAPANESE INTERMEDIATE CODE: R250 |
|
| R250 | Receipt of annual fees |
Free format text: JAPANESE INTERMEDIATE CODE: R250 |
|
| R250 | Receipt of annual fees |
Free format text: JAPANESE INTERMEDIATE CODE: R250 |
|
| R250 | Receipt of annual fees |
Free format text: JAPANESE INTERMEDIATE CODE: R250 |
|
| R250 | Receipt of annual fees |
Free format text: JAPANESE INTERMEDIATE CODE: R250 |
|
| R250 | Receipt of annual fees |
Free format text: JAPANESE INTERMEDIATE CODE: R250 |
|
| R250 | Receipt of annual fees |
Free format text: JAPANESE INTERMEDIATE CODE: R250 |