KR20200095976A - 운전자 보조 장치 - Google Patents
운전자 보조 장치 Download PDFInfo
- Publication number
- KR20200095976A KR20200095976A KR1020190014039A KR20190014039A KR20200095976A KR 20200095976 A KR20200095976 A KR 20200095976A KR 1020190014039 A KR1020190014039 A KR 1020190014039A KR 20190014039 A KR20190014039 A KR 20190014039A KR 20200095976 A KR20200095976 A KR 20200095976A
- Authority
- KR
- South Korea
- Prior art keywords
- vehicle
- collision
- driver assistance
- control unit
- steering
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Granted
Links
Images

Classifications
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B60—VEHICLES IN GENERAL
- B60W—CONJOINT CONTROL OF VEHICLE SUB-UNITS OF DIFFERENT TYPE OR DIFFERENT FUNCTION; CONTROL SYSTEMS SPECIALLY ADAPTED FOR HYBRID VEHICLES; ROAD VEHICLE DRIVE CONTROL SYSTEMS FOR PURPOSES NOT RELATED TO THE CONTROL OF A PARTICULAR SUB-UNIT
- B60W30/00—Purposes of road vehicle drive control systems not related to the control of a particular sub-unit, e.g. of systems using conjoint control of vehicle sub-units
- B60W30/08—Active safety systems predicting or avoiding probable or impending collision or attempting to minimise its consequences
-
- G—PHYSICS
- G01—MEASURING; TESTING
- G01S—RADIO DIRECTION-FINDING; RADIO NAVIGATION; DETERMINING DISTANCE OR VELOCITY BY USE OF RADIO WAVES; LOCATING OR PRESENCE-DETECTING BY USE OF THE REFLECTION OR RERADIATION OF RADIO WAVES; ANALOGOUS ARRANGEMENTS USING OTHER WAVES
- G01S17/00—Systems using the reflection or reradiation of electromagnetic waves other than radio waves, e.g. lidar systems
- G01S17/88—Lidar systems specially adapted for specific applications
- G01S17/93—Lidar systems specially adapted for specific applications for anti-collision purposes
- G01S17/931—Lidar systems specially adapted for specific applications for anti-collision purposes of land vehicles
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B60—VEHICLES IN GENERAL
- B60R—VEHICLES, VEHICLE FITTINGS, OR VEHICLE PARTS, NOT OTHERWISE PROVIDED FOR
- B60R21/00—Arrangements or fittings on vehicles for protecting or preventing injuries to occupants or pedestrians in case of accidents or other traffic risks
- B60R21/01—Electrical circuits for triggering passive safety arrangements, e.g. airbags, safety belt tighteners, in case of vehicle accidents or impending vehicle accidents
- B60R21/013—Electrical circuits for triggering passive safety arrangements, e.g. airbags, safety belt tighteners, in case of vehicle accidents or impending vehicle accidents including means for detecting collisions, impending collisions or roll-over
- B60R21/0134—Electrical circuits for triggering passive safety arrangements, e.g. airbags, safety belt tighteners, in case of vehicle accidents or impending vehicle accidents including means for detecting collisions, impending collisions or roll-over responsive to imminent contact with an obstacle, e.g. using radar systems
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B60—VEHICLES IN GENERAL
- B60W—CONJOINT CONTROL OF VEHICLE SUB-UNITS OF DIFFERENT TYPE OR DIFFERENT FUNCTION; CONTROL SYSTEMS SPECIALLY ADAPTED FOR HYBRID VEHICLES; ROAD VEHICLE DRIVE CONTROL SYSTEMS FOR PURPOSES NOT RELATED TO THE CONTROL OF A PARTICULAR SUB-UNIT
- B60W10/00—Conjoint control of vehicle sub-units of different type or different function
- B60W10/18—Conjoint control of vehicle sub-units of different type or different function including control of braking systems
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B60—VEHICLES IN GENERAL
- B60W—CONJOINT CONTROL OF VEHICLE SUB-UNITS OF DIFFERENT TYPE OR DIFFERENT FUNCTION; CONTROL SYSTEMS SPECIALLY ADAPTED FOR HYBRID VEHICLES; ROAD VEHICLE DRIVE CONTROL SYSTEMS FOR PURPOSES NOT RELATED TO THE CONTROL OF A PARTICULAR SUB-UNIT
- B60W10/00—Conjoint control of vehicle sub-units of different type or different function
- B60W10/20—Conjoint control of vehicle sub-units of different type or different function including control of steering systems
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B60—VEHICLES IN GENERAL
- B60W—CONJOINT CONTROL OF VEHICLE SUB-UNITS OF DIFFERENT TYPE OR DIFFERENT FUNCTION; CONTROL SYSTEMS SPECIALLY ADAPTED FOR HYBRID VEHICLES; ROAD VEHICLE DRIVE CONTROL SYSTEMS FOR PURPOSES NOT RELATED TO THE CONTROL OF A PARTICULAR SUB-UNIT
- B60W30/00—Purposes of road vehicle drive control systems not related to the control of a particular sub-unit, e.g. of systems using conjoint control of vehicle sub-units
- B60W30/08—Active safety systems predicting or avoiding probable or impending collision or attempting to minimise its consequences
- B60W30/09—Taking automatic action to avoid collision, e.g. braking and steering
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B60—VEHICLES IN GENERAL
- B60W—CONJOINT CONTROL OF VEHICLE SUB-UNITS OF DIFFERENT TYPE OR DIFFERENT FUNCTION; CONTROL SYSTEMS SPECIALLY ADAPTED FOR HYBRID VEHICLES; ROAD VEHICLE DRIVE CONTROL SYSTEMS FOR PURPOSES NOT RELATED TO THE CONTROL OF A PARTICULAR SUB-UNIT
- B60W30/00—Purposes of road vehicle drive control systems not related to the control of a particular sub-unit, e.g. of systems using conjoint control of vehicle sub-units
- B60W30/08—Active safety systems predicting or avoiding probable or impending collision or attempting to minimise its consequences
- B60W30/095—Predicting travel path or likelihood of collision
- B60W30/0956—Predicting travel path or likelihood of collision the prediction being responsive to traffic or environmental parameters
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B60—VEHICLES IN GENERAL
- B60W—CONJOINT CONTROL OF VEHICLE SUB-UNITS OF DIFFERENT TYPE OR DIFFERENT FUNCTION; CONTROL SYSTEMS SPECIALLY ADAPTED FOR HYBRID VEHICLES; ROAD VEHICLE DRIVE CONTROL SYSTEMS FOR PURPOSES NOT RELATED TO THE CONTROL OF A PARTICULAR SUB-UNIT
- B60W30/00—Purposes of road vehicle drive control systems not related to the control of a particular sub-unit, e.g. of systems using conjoint control of vehicle sub-units
- B60W30/10—Path keeping
- B60W30/12—Lane keeping
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B60—VEHICLES IN GENERAL
- B60W—CONJOINT CONTROL OF VEHICLE SUB-UNITS OF DIFFERENT TYPE OR DIFFERENT FUNCTION; CONTROL SYSTEMS SPECIALLY ADAPTED FOR HYBRID VEHICLES; ROAD VEHICLE DRIVE CONTROL SYSTEMS FOR PURPOSES NOT RELATED TO THE CONTROL OF A PARTICULAR SUB-UNIT
- B60W40/00—Estimation or calculation of non-directly measurable driving parameters for road vehicle drive control systems not related to the control of a particular sub unit, e.g. by using mathematical models
- B60W40/02—Estimation or calculation of non-directly measurable driving parameters for road vehicle drive control systems not related to the control of a particular sub unit, e.g. by using mathematical models related to ambient conditions
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B60—VEHICLES IN GENERAL
- B60W—CONJOINT CONTROL OF VEHICLE SUB-UNITS OF DIFFERENT TYPE OR DIFFERENT FUNCTION; CONTROL SYSTEMS SPECIALLY ADAPTED FOR HYBRID VEHICLES; ROAD VEHICLE DRIVE CONTROL SYSTEMS FOR PURPOSES NOT RELATED TO THE CONTROL OF A PARTICULAR SUB-UNIT
- B60W40/00—Estimation or calculation of non-directly measurable driving parameters for road vehicle drive control systems not related to the control of a particular sub unit, e.g. by using mathematical models
- B60W40/10—Estimation or calculation of non-directly measurable driving parameters for road vehicle drive control systems not related to the control of a particular sub unit, e.g. by using mathematical models related to vehicle motion
- B60W40/114—Yaw movement
-
- G—PHYSICS
- G01—MEASURING; TESTING
- G01S—RADIO DIRECTION-FINDING; RADIO NAVIGATION; DETERMINING DISTANCE OR VELOCITY BY USE OF RADIO WAVES; LOCATING OR PRESENCE-DETECTING BY USE OF THE REFLECTION OR RERADIATION OF RADIO WAVES; ANALOGOUS ARRANGEMENTS USING OTHER WAVES
- G01S13/00—Systems using the reflection or reradiation of radio waves, e.g. radar systems; Analogous systems using reflection or reradiation of waves whose nature or wavelength is irrelevant or unspecified
- G01S13/86—Combinations of radar systems with non-radar systems, e.g. sonar, direction finder
- G01S13/865—Combination of radar systems with lidar systems
-
- G—PHYSICS
- G01—MEASURING; TESTING
- G01S—RADIO DIRECTION-FINDING; RADIO NAVIGATION; DETERMINING DISTANCE OR VELOCITY BY USE OF RADIO WAVES; LOCATING OR PRESENCE-DETECTING BY USE OF THE REFLECTION OR RERADIATION OF RADIO WAVES; ANALOGOUS ARRANGEMENTS USING OTHER WAVES
- G01S13/00—Systems using the reflection or reradiation of radio waves, e.g. radar systems; Analogous systems using reflection or reradiation of waves whose nature or wavelength is irrelevant or unspecified
- G01S13/86—Combinations of radar systems with non-radar systems, e.g. sonar, direction finder
- G01S13/867—Combination of radar systems with cameras
-
- G—PHYSICS
- G01—MEASURING; TESTING
- G01S—RADIO DIRECTION-FINDING; RADIO NAVIGATION; DETERMINING DISTANCE OR VELOCITY BY USE OF RADIO WAVES; LOCATING OR PRESENCE-DETECTING BY USE OF THE REFLECTION OR RERADIATION OF RADIO WAVES; ANALOGOUS ARRANGEMENTS USING OTHER WAVES
- G01S13/00—Systems using the reflection or reradiation of radio waves, e.g. radar systems; Analogous systems using reflection or reradiation of waves whose nature or wavelength is irrelevant or unspecified
- G01S13/88—Radar or analogous systems specially adapted for specific applications
- G01S13/93—Radar or analogous systems specially adapted for specific applications for anti-collision purposes
- G01S13/931—Radar or analogous systems specially adapted for specific applications for anti-collision purposes of land vehicles
-
- G—PHYSICS
- G01—MEASURING; TESTING
- G01S—RADIO DIRECTION-FINDING; RADIO NAVIGATION; DETERMINING DISTANCE OR VELOCITY BY USE OF RADIO WAVES; LOCATING OR PRESENCE-DETECTING BY USE OF THE REFLECTION OR RERADIATION OF RADIO WAVES; ANALOGOUS ARRANGEMENTS USING OTHER WAVES
- G01S17/00—Systems using the reflection or reradiation of electromagnetic waves other than radio waves, e.g. lidar systems
- G01S17/86—Combinations of lidar systems with systems other than lidar, radar or sonar, e.g. with direction finders
-
- G—PHYSICS
- G08—SIGNALLING
- G08G—TRAFFIC CONTROL SYSTEMS
- G08G1/00—Traffic control systems for road vehicles
- G08G1/16—Anti-collision systems
- G08G1/161—Decentralised systems, e.g. inter-vehicle communication
- G08G1/163—Decentralised systems, e.g. inter-vehicle communication involving continuous checking
-
- G—PHYSICS
- G08—SIGNALLING
- G08G—TRAFFIC CONTROL SYSTEMS
- G08G1/00—Traffic control systems for road vehicles
- G08G1/16—Anti-collision systems
- G08G1/166—Anti-collision systems for active traffic, e.g. moving vehicles, pedestrians, bikes
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B60—VEHICLES IN GENERAL
- B60W—CONJOINT CONTROL OF VEHICLE SUB-UNITS OF DIFFERENT TYPE OR DIFFERENT FUNCTION; CONTROL SYSTEMS SPECIALLY ADAPTED FOR HYBRID VEHICLES; ROAD VEHICLE DRIVE CONTROL SYSTEMS FOR PURPOSES NOT RELATED TO THE CONTROL OF A PARTICULAR SUB-UNIT
- B60W50/00—Details of control systems for road vehicle drive control not related to the control of a particular sub-unit, e.g. process diagnostic or vehicle driver interfaces
- B60W2050/0001—Details of the control system
- B60W2050/0002—Automatic control, details of type of controller or control system architecture
- B60W2050/0004—In digital systems, e.g. discrete-time systems involving sampling
- B60W2050/0005—Processor details or data handling, e.g. memory registers or chip architecture
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B60—VEHICLES IN GENERAL
- B60W—CONJOINT CONTROL OF VEHICLE SUB-UNITS OF DIFFERENT TYPE OR DIFFERENT FUNCTION; CONTROL SYSTEMS SPECIALLY ADAPTED FOR HYBRID VEHICLES; ROAD VEHICLE DRIVE CONTROL SYSTEMS FOR PURPOSES NOT RELATED TO THE CONTROL OF A PARTICULAR SUB-UNIT
- B60W2420/00—Indexing codes relating to the type of sensors based on the principle of their operation
- B60W2420/40—Photo, light or radio wave sensitive means, e.g. infrared sensors
- B60W2420/403—Image sensing, e.g. optical camera
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B60—VEHICLES IN GENERAL
- B60W—CONJOINT CONTROL OF VEHICLE SUB-UNITS OF DIFFERENT TYPE OR DIFFERENT FUNCTION; CONTROL SYSTEMS SPECIALLY ADAPTED FOR HYBRID VEHICLES; ROAD VEHICLE DRIVE CONTROL SYSTEMS FOR PURPOSES NOT RELATED TO THE CONTROL OF A PARTICULAR SUB-UNIT
- B60W2420/00—Indexing codes relating to the type of sensors based on the principle of their operation
- B60W2420/40—Photo, light or radio wave sensitive means, e.g. infrared sensors
- B60W2420/408—Radar; Laser, e.g. lidar
-
- B60W2420/42—
-
- B60W2420/52—
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B60—VEHICLES IN GENERAL
- B60W—CONJOINT CONTROL OF VEHICLE SUB-UNITS OF DIFFERENT TYPE OR DIFFERENT FUNCTION; CONTROL SYSTEMS SPECIALLY ADAPTED FOR HYBRID VEHICLES; ROAD VEHICLE DRIVE CONTROL SYSTEMS FOR PURPOSES NOT RELATED TO THE CONTROL OF A PARTICULAR SUB-UNIT
- B60W2552/00—Input parameters relating to infrastructure
- B60W2552/53—Road markings, e.g. lane marker or crosswalk
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B60—VEHICLES IN GENERAL
- B60W—CONJOINT CONTROL OF VEHICLE SUB-UNITS OF DIFFERENT TYPE OR DIFFERENT FUNCTION; CONTROL SYSTEMS SPECIALLY ADAPTED FOR HYBRID VEHICLES; ROAD VEHICLE DRIVE CONTROL SYSTEMS FOR PURPOSES NOT RELATED TO THE CONTROL OF A PARTICULAR SUB-UNIT
- B60W2554/00—Input parameters relating to objects
- B60W2554/80—Spatial relation or speed relative to objects
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B60—VEHICLES IN GENERAL
- B60W—CONJOINT CONTROL OF VEHICLE SUB-UNITS OF DIFFERENT TYPE OR DIFFERENT FUNCTION; CONTROL SYSTEMS SPECIALLY ADAPTED FOR HYBRID VEHICLES; ROAD VEHICLE DRIVE CONTROL SYSTEMS FOR PURPOSES NOT RELATED TO THE CONTROL OF A PARTICULAR SUB-UNIT
- B60W2720/00—Output or target parameters relating to overall vehicle dynamics
- B60W2720/14—Yaw
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B60—VEHICLES IN GENERAL
- B60Y—INDEXING SCHEME RELATING TO ASPECTS CROSS-CUTTING VEHICLE TECHNOLOGY
- B60Y2300/00—Purposes or special features of road vehicle drive control systems
- B60Y2300/08—Predicting or avoiding probable or impending collision
-
- G—PHYSICS
- G01—MEASURING; TESTING
- G01S—RADIO DIRECTION-FINDING; RADIO NAVIGATION; DETERMINING DISTANCE OR VELOCITY BY USE OF RADIO WAVES; LOCATING OR PRESENCE-DETECTING BY USE OF THE REFLECTION OR RERADIATION OF RADIO WAVES; ANALOGOUS ARRANGEMENTS USING OTHER WAVES
- G01S13/00—Systems using the reflection or reradiation of radio waves, e.g. radar systems; Analogous systems using reflection or reradiation of waves whose nature or wavelength is irrelevant or unspecified
- G01S13/88—Radar or analogous systems specially adapted for specific applications
- G01S13/93—Radar or analogous systems specially adapted for specific applications for anti-collision purposes
- G01S13/931—Radar or analogous systems specially adapted for specific applications for anti-collision purposes of land vehicles
- G01S2013/9318—Controlling the steering
-
- G—PHYSICS
- G01—MEASURING; TESTING
- G01S—RADIO DIRECTION-FINDING; RADIO NAVIGATION; DETERMINING DISTANCE OR VELOCITY BY USE OF RADIO WAVES; LOCATING OR PRESENCE-DETECTING BY USE OF THE REFLECTION OR RERADIATION OF RADIO WAVES; ANALOGOUS ARRANGEMENTS USING OTHER WAVES
- G01S13/00—Systems using the reflection or reradiation of radio waves, e.g. radar systems; Analogous systems using reflection or reradiation of waves whose nature or wavelength is irrelevant or unspecified
- G01S13/88—Radar or analogous systems specially adapted for specific applications
- G01S13/93—Radar or analogous systems specially adapted for specific applications for anti-collision purposes
- G01S13/931—Radar or analogous systems specially adapted for specific applications for anti-collision purposes of land vehicles
- G01S2013/93185—Controlling the brakes
-
- G—PHYSICS
- G01—MEASURING; TESTING
- G01S—RADIO DIRECTION-FINDING; RADIO NAVIGATION; DETERMINING DISTANCE OR VELOCITY BY USE OF RADIO WAVES; LOCATING OR PRESENCE-DETECTING BY USE OF THE REFLECTION OR RERADIATION OF RADIO WAVES; ANALOGOUS ARRANGEMENTS USING OTHER WAVES
- G01S13/00—Systems using the reflection or reradiation of radio waves, e.g. radar systems; Analogous systems using reflection or reradiation of waves whose nature or wavelength is irrelevant or unspecified
- G01S13/88—Radar or analogous systems specially adapted for specific applications
- G01S13/93—Radar or analogous systems specially adapted for specific applications for anti-collision purposes
- G01S13/931—Radar or analogous systems specially adapted for specific applications for anti-collision purposes of land vehicles
- G01S2013/9327—Sensor installation details
- G01S2013/93271—Sensor installation details in the front of the vehicles
-
- G—PHYSICS
- G01—MEASURING; TESTING
- G01S—RADIO DIRECTION-FINDING; RADIO NAVIGATION; DETERMINING DISTANCE OR VELOCITY BY USE OF RADIO WAVES; LOCATING OR PRESENCE-DETECTING BY USE OF THE REFLECTION OR RERADIATION OF RADIO WAVES; ANALOGOUS ARRANGEMENTS USING OTHER WAVES
- G01S13/00—Systems using the reflection or reradiation of radio waves, e.g. radar systems; Analogous systems using reflection or reradiation of waves whose nature or wavelength is irrelevant or unspecified
- G01S13/88—Radar or analogous systems specially adapted for specific applications
- G01S13/93—Radar or analogous systems specially adapted for specific applications for anti-collision purposes
- G01S13/931—Radar or analogous systems specially adapted for specific applications for anti-collision purposes of land vehicles
- G01S2013/9327—Sensor installation details
- G01S2013/93272—Sensor installation details in the back of the vehicles
-
- G—PHYSICS
- G01—MEASURING; TESTING
- G01S—RADIO DIRECTION-FINDING; RADIO NAVIGATION; DETERMINING DISTANCE OR VELOCITY BY USE OF RADIO WAVES; LOCATING OR PRESENCE-DETECTING BY USE OF THE REFLECTION OR RERADIATION OF RADIO WAVES; ANALOGOUS ARRANGEMENTS USING OTHER WAVES
- G01S13/00—Systems using the reflection or reradiation of radio waves, e.g. radar systems; Analogous systems using reflection or reradiation of waves whose nature or wavelength is irrelevant or unspecified
- G01S13/88—Radar or analogous systems specially adapted for specific applications
- G01S13/93—Radar or analogous systems specially adapted for specific applications for anti-collision purposes
- G01S13/931—Radar or analogous systems specially adapted for specific applications for anti-collision purposes of land vehicles
- G01S2013/9327—Sensor installation details
- G01S2013/93274—Sensor installation details on the side of the vehicles
Landscapes
- Engineering & Computer Science (AREA)
- Mechanical Engineering (AREA)
- Transportation (AREA)
- Remote Sensing (AREA)
- Radar, Positioning & Navigation (AREA)
- Physics & Mathematics (AREA)
- Automation & Control Theory (AREA)
- General Physics & Mathematics (AREA)
- Chemical & Material Sciences (AREA)
- Combustion & Propulsion (AREA)
- Computer Networks & Wireless Communication (AREA)
- Electromagnetism (AREA)
- Mathematical Physics (AREA)
- Traffic Control Systems (AREA)
Abstract
Description
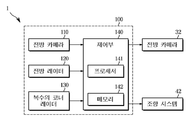
도 2은 일 실시예에 의한 운전자 보조 시스템의 구성을 도시한다.
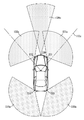
도 3은 일 실시예에 의한 운전자 보조 시스템에 포함된 카메라 및 레이더를 도시한다.
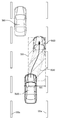
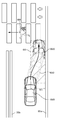
도 4는 일 실시예에 의한 운전자 보조 시스템을 장착한 차량이 선행 장애물을 감지하는 방법을 설명하는 개략도이다.
도 5는 일 실시예에 의한 운전자 보조 시스템을 장착한 차량이 선행 차량과의 충돌을 피하는 방법을 설명하는 개략도이다.
도 6는 일 실시예에 의한 운전자 보조 시스템을 장착한 차량이 보행자와의 충돌을 피하는 방법을 설명하는 개략도이다.
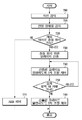
도 7은 일 실시예에 의한 운전자 보조 시스템의 동작 방법을 설명하는 순서도이다.
100: 운전자 보조 시스템
110: 전방 카메라
120: 전방 레이더
130: 복수의 코너 레이더들
131: 제1 코너 레이더
132: 제2 코너 레이더
133: 제3 코너 레이더
134: 제4 코너 레이더
140: 제어부
Claims (15)
- 차량에 설치되어, 상기 차량의 전방 시야를 가지며, 전방 영상 데이터를 획득하는 전방 영상 센서;
레이더 센서와 라이더 센서로 구성된 그룹에서 선택되어, 상기 차량에 설치되며, 상기 차량의 전방의 감지 시야를 가지고, 전방 감지 데이터를 획득하는 비-영상 센서;
상기 전방 영상 데이터와 상기 전방 감지 데이터를 처리하는 프로세서를 포함하는 제어부를 포함하고,
상기 제어부는, 상기 영상 데이터와 상기 전방 감지 데이터를 처리한 것에 응답하여, 상기 차량이 주행중인 차선을 감지하고, 또는 상기 차량의 전방에 위치하는 전방 장애물을 감지하고,
상기 제어부는, 상기 차량의 상기 전방 객체와의 충돌이 예상되면 상기 차량의 제동 장치로 제동 신호를 출력하고,
상기 제어부는, 상기 제동 신호를 출력하여도 상기 전방 객체와의 충돌이 예상되면, 상기 차량의 조향 장치로 조향 신호를 출력하는 운전자 보조 시스템. - 제 1 항에 있어서,
상기 제어부는, 상기 전방 장애물과 충돌이 예상되는 경우에, 상기 전방 장애물과 충돌을 피하고, 상기 차량이 주행중인 차선 내에서 상기 차량이 주행하도록 상기 차량의 조향 장치로 조향 신호를 출력하는 운전자 보조 시스템. - 제 1 항에 있어서,
상기 제어부는, 상기 전방 장애물과 충돌을 피하고, 상기 차량이 주행 중인 차선 내에서 상기 차량이 주행하기 위하여 요구되는 요레이트를 산출하는 운전자 보조 시스템. - 제 3 항에 있어서,
상기 제어부는, 상기 차량이 상기 전방 장애물과 충돌을 피하고, 상기 차량이 주행 중인 차선 내 미리 설정된 영역 내에서 주행하도록 상기 차량의 조향 장치에 조향 신호를 출력하고, 상기 차량의 제동 장치에 제동 신호를 출력하는 운전자 보조 시스템. - 제 4 항에 있어서,
상기 제어부는, 상기 차량과 상기 전방 장애물 사이의 거리 및 상기 차선의폭으로 이루어진 영역보다 좁은 상기 미리 설정된 영역을 포함하는 운전자 보조 시스템. - 제 5 항에 있어서,
상기 제어부는, 상기 미리 설정된 영역 내에서 상기 차량이 주행하기 위하여 요구되는 요레이트를 실시간으로 산출하는 운전자 보조 시스템. - 제 6항에 있어서,
상기 제어부는 실시간으로 산출되는 요레이트에 따라 상기 조향 장치로 변경된 조향 제어 신호를 출력하는 운전자 보조 시스템. - 제 7항에 있어서,
상기 제어부는, 상기 전방 객체까지 거리와 상기 전방 객체의 상대 속도에 기초하여, 상기 차량과 상기 전방 객체의 충돌을 예상하는 운전자 보조 시스템. - 차량에 설치되어 상기 차량의 전방 시야를 가지는 카메라에 의하여, 상기 차량의 전방 영상 데이터를 획득하고;
상기 차량에 설치되어 상기 차량의 전방 감지 시야를 가지는 전방 레이더에 의하여, 상기 차량의 전방 레이더 데이터를 획득하고;
상기 영상 데이터와 상기 전방 감지 데이터를 처리한 것에 응답하여, 상기 차량이 주행중인 차선을 감지하고, 또는 상기 차량의 전방에 위치하는 전방 장애물을 감지하고;
상기 차량의 상기 전방 객체와의 충돌이 예상되면 상기 차량을 제동시키고;
상기 차량의 제동에도 상기 전방 객체와의 충돌이 예상되면, 상기 차량의 주행 방향을 변경하는 것을 운전자 보조 방법. - 제 9항에 있어서,
상기 운전자 보조 방법은, 상기 전방 장애물과 충돌이 예상되는 경우에, 상기 전방 장애물과 충돌을 피하고, 상기 차량이 주행중인 차선 내에서 상기 차량이 주행하도록 상기 차량의 주행 방향을 변경하는 것을 더 포함하는 운전자 보조 방법. - 제 9 항에 있어서,
상기 운전자 보조 방법은, 상기 전방 장애물과 충돌을 피하고, 상기 차량이 주행 중인 차선 내에서 상기 차량이 주행하기 위하여 요구되는 요레이트를 산출하는 것을 더 포함하는 운전자 보조 방법. - 제 11 항에 있어서,
상기 운전자 보조 방법은, 상기 차량이 상기 전방 장애물과 충돌을 피하고, 상기 차량이 주행 중인 차선 내 미리 설정된 영역 내에서 주행하도록 상기 차량의 주행 방향을 변경시키고, 상기 차량을 제동 시키는 운전자 보조 방법. - 제 12 항에 있어서,
상기 운전자 보조 방법은, 상기 미리 설정된 영역 내에서 상기 차량이 주행하기 위하여 요구되는 요레이트를 실시간으로 산출하는 것을 더 포함하는 운전자 보조 방법. - 제 13항에 있어서,
상기 운전자 보조 방법은, 실시간으로 산출되는 요레이트에 따라 상기 조향 장치로 변경된 조향 제어 신호를 출력하는 것을 더 포함하는 운전자 보조 방법. - 제 14항에 있어서,
상기 운전자 보조 방법은, 상기 전방 객체까지 거리와 상기 전방 객체의 상대 속도에 기초하여, 상기 차량과 상기 전방 객체의 충돌을 예상하는 것을 더 포함하는 운전자 보조 방법.
Priority Applications (4)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| KR1020190014039A KR102695891B1 (ko) | 2019-02-01 | 2019-02-01 | 운전자 보조 장치 |
| US16/737,294 US11505183B2 (en) | 2019-02-01 | 2020-01-08 | Driver assistance system and method |
| DE102020201010.2A DE102020201010A1 (de) | 2019-02-01 | 2020-01-28 | Fahrerassistenzsystem und -verfahren |
| CN202010077653.5A CN111516678B (zh) | 2019-02-01 | 2020-01-31 | 驾驶员辅助系统和方法 |
Applications Claiming Priority (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| KR1020190014039A KR102695891B1 (ko) | 2019-02-01 | 2019-02-01 | 운전자 보조 장치 |
Publications (2)
| Publication Number | Publication Date |
|---|---|
| KR20200095976A true KR20200095976A (ko) | 2020-08-11 |
| KR102695891B1 KR102695891B1 (ko) | 2024-08-16 |
Family
ID=71615540
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| KR1020190014039A Active KR102695891B1 (ko) | 2019-02-01 | 2019-02-01 | 운전자 보조 장치 |
Country Status (4)
| Country | Link |
|---|---|
| US (1) | US11505183B2 (ko) |
| KR (1) | KR102695891B1 (ko) |
| CN (1) | CN111516678B (ko) |
| DE (1) | DE102020201010A1 (ko) |
Cited By (1)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| KR102195881B1 (ko) * | 2020-09-28 | 2020-12-29 | 김병준 | 안전운전을 위해 사각지대의 정보를 제공하는 장치 |
Families Citing this family (11)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JP7065069B2 (ja) * | 2019-12-25 | 2022-05-11 | 本田技研工業株式会社 | 移動体の制御装置 |
| FR3114287B1 (fr) | 2020-09-22 | 2023-05-12 | Valeo Vision | Système d’aide à la conduite d’un véhicule |
| EP3974868A1 (en) * | 2020-09-29 | 2022-03-30 | Inalfa Roof Systems Group B.V. | Sensor system mountable on the roof of a car. |
| US11608089B2 (en) * | 2020-11-09 | 2023-03-21 | GM Global Technology Operations LLC | Method and apparatus for automated lateral controls adaptation in response to rapid trajectory changes |
| JP7347405B2 (ja) * | 2020-11-30 | 2023-09-20 | トヨタ自動車株式会社 | 運転支援システム |
| WO2022183023A1 (en) * | 2021-02-25 | 2022-09-01 | Autonomous Solutions, Inc. | Intelligent urgent stop system for an autonomous vehicle |
| KR20220164127A (ko) * | 2021-06-03 | 2022-12-13 | 현대자동차주식회사 | 충돌 회피 측면 이동 시스템 |
| EP4140842B1 (en) * | 2021-08-26 | 2024-06-05 | Aptiv Technologies AG | Methods and systems for controlling a vehicle |
| KR102712175B1 (ko) * | 2021-09-17 | 2024-09-30 | 주식회사 에이치엘클레무브 | 차량의 주행을 보조하는 장치 및 그 방법 |
| JP7768806B2 (ja) * | 2022-03-11 | 2025-11-12 | 株式会社Subaru | 車両制御装置 |
| KR20240031445A (ko) * | 2022-08-29 | 2024-03-08 | 현대자동차주식회사 | 자율주행차량의 수동주행모드 전환 제어 방법 |
Citations (2)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| KR20170026193A (ko) * | 2015-08-28 | 2017-03-08 | 도요타지도샤가부시키가이샤 | 충돌 회피 지원 장치 |
| JP2017134519A (ja) * | 2016-01-26 | 2017-08-03 | トヨタ自動車株式会社 | 車両用衝突回避支援システム |
Family Cites Families (14)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JP3197307B2 (ja) * | 1991-10-14 | 2001-08-13 | マツダ株式会社 | 移動車の走行制御装置 |
| JP4290455B2 (ja) * | 2003-03-28 | 2009-07-08 | 日産自動車株式会社 | 車両用制動制御装置 |
| JP2009061878A (ja) * | 2007-09-05 | 2009-03-26 | Toyota Motor Corp | 走行制御装置 |
| KR101361360B1 (ko) | 2011-12-26 | 2014-02-11 | 현대자동차주식회사 | 측후방 감지센서를 이용한 차간거리 제어 시스템 및 그 제어 방법 |
| KR20140126975A (ko) * | 2013-04-24 | 2014-11-03 | 주식회사 만도 | 차량의 충돌 회피 장치 및 방법 |
| JP6049542B2 (ja) * | 2013-05-31 | 2016-12-21 | 日立オートモティブシステムズ株式会社 | 車両制御システム |
| KR101582572B1 (ko) * | 2013-12-24 | 2016-01-11 | 엘지전자 주식회사 | 차량 운전 보조 장치 및 이를 구비한 차량 |
| JP6036724B2 (ja) * | 2014-02-17 | 2016-11-30 | トヨタ自動車株式会社 | 車両周辺状況認識装置および車両制御装置 |
| KR101628503B1 (ko) * | 2014-10-27 | 2016-06-08 | 현대자동차주식회사 | 운전자 보조장치 및 그 작동 방법 |
| KR101834351B1 (ko) | 2016-07-14 | 2018-03-05 | 엘지전자 주식회사 | 차량용 운전 보조 장치 |
| KR102671554B1 (ko) * | 2016-12-08 | 2024-06-04 | 현대자동차주식회사 | 차량 및 그 제어방법 |
| KR101996419B1 (ko) * | 2016-12-30 | 2019-07-04 | 현대자동차주식회사 | 센서 융합 기반 보행자 탐지 및 보행자 충돌 방지 장치 및 방법 |
| JP6859902B2 (ja) * | 2017-08-31 | 2021-04-14 | トヨタ自動車株式会社 | 車両制御装置 |
| KR101982089B1 (ko) | 2019-01-29 | 2019-05-24 | (주)큐라움 | 스핀코팅 기술과 동결건조 기술을 융합한 삼중층 다공성 생체활성막 제조 방법 및 그에 의해 제조된 삼중층 다공성 생체활성막 |
-
2019
- 2019-02-01 KR KR1020190014039A patent/KR102695891B1/ko active Active
-
2020
- 2020-01-08 US US16/737,294 patent/US11505183B2/en active Active
- 2020-01-28 DE DE102020201010.2A patent/DE102020201010A1/de active Pending
- 2020-01-31 CN CN202010077653.5A patent/CN111516678B/zh active Active
Patent Citations (2)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| KR20170026193A (ko) * | 2015-08-28 | 2017-03-08 | 도요타지도샤가부시키가이샤 | 충돌 회피 지원 장치 |
| JP2017134519A (ja) * | 2016-01-26 | 2017-08-03 | トヨタ自動車株式会社 | 車両用衝突回避支援システム |
Cited By (2)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| KR102195881B1 (ko) * | 2020-09-28 | 2020-12-29 | 김병준 | 안전운전을 위해 사각지대의 정보를 제공하는 장치 |
| KR20220042985A (ko) * | 2020-09-28 | 2022-04-05 | 김병준 | 운전할 때 발생하는 사각지대에 대한 정보를 제공하는 안전 시스템 |
Also Published As
| Publication number | Publication date |
|---|---|
| KR102695891B1 (ko) | 2024-08-16 |
| CN111516678B (zh) | 2025-02-14 |
| US20200247397A1 (en) | 2020-08-06 |
| DE102020201010A1 (de) | 2020-08-06 |
| US11505183B2 (en) | 2022-11-22 |
| CN111516678A (zh) | 2020-08-11 |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| KR102715606B1 (ko) | 운전자 보조 시스템, 그를 가지는 차량 및 그 제어 방법 | |
| CN111497833B (zh) | 驾驶员辅助系统及其控制方法 | |
| KR102695891B1 (ko) | 운전자 보조 장치 | |
| US12091013B2 (en) | Advanced driver assistance system, vehicle having the same and method for controlling the vehicle | |
| US11840223B2 (en) | Driver assistant system and method of controlling the same | |
| EP3644090A1 (en) | Driver assistance system and control method thereof | |
| CN113060141A (zh) | 高级驾驶员辅助系统、具有其的车辆及控制车辆的方法 | |
| KR102572785B1 (ko) | 운전자 보조 시스템 | |
| US11840220B2 (en) | Driver assistance system and control method thereof | |
| US11634120B2 (en) | Driver assistance system and driver assistance method | |
| KR20200115827A (ko) | 운전자 보조 시스템 및 그 제어 방법 | |
| US12091000B2 (en) | Driver assistance system and control method thereof | |
| KR20200139443A (ko) | 운전자 보조 시스템 및 그 제어 방법 | |
| US12043310B2 (en) | Driver assistance system and control method for the same | |
| KR20220166119A (ko) | 운전자 보조 시스템 및 그 제어 방법 | |
| KR102440265B1 (ko) | 운전자 보조 시스템 | |
| KR102700168B1 (ko) | 운전자 보조 시스템 | |
| KR20200094629A (ko) | 운전자 보조 시스템 및 그 제어 방법 | |
| KR20210080717A (ko) | 운전자 보조 장치 및 운전자 보조 방법 | |
| KR102936876B1 (ko) | 차량 및 그 제어 방법 | |
| KR102712175B1 (ko) | 차량의 주행을 보조하는 장치 및 그 방법 | |
| US20220410879A1 (en) | Vehicle and control method thereof | |
| KR102413484B1 (ko) | 운전자 보조 시스템 및 그 방법 | |
| KR102833993B1 (ko) | 차로 변경 유도장치 및 그 제어방법. | |
| KR20220085084A (ko) | 운전자 보조 시스템 및 그 제어 방법 |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| PA0109 | Patent application |
Patent event code: PA01091R01D Comment text: Patent Application Patent event date: 20190201 |
|
| PG1501 | Laying open of application | ||
| N231 | Notification of change of applicant | ||
| PN2301 | Change of applicant |
Patent event date: 20211001 Comment text: Notification of Change of Applicant Patent event code: PN23011R01D |
|
| A201 | Request for examination | ||
| PA0201 | Request for examination |
Patent event code: PA02012R01D Patent event date: 20220126 Comment text: Request for Examination of Application Patent event code: PA02011R01I Patent event date: 20190201 Comment text: Patent Application |
|
| N231 | Notification of change of applicant | ||
| PN2301 | Change of applicant |
Patent event date: 20220412 Comment text: Notification of Change of Applicant Patent event code: PN23011R01D |
|
| E902 | Notification of reason for refusal | ||
| PE0902 | Notice of grounds for rejection |
Comment text: Notification of reason for refusal Patent event date: 20231207 Patent event code: PE09021S01D |
|
| E701 | Decision to grant or registration of patent right | ||
| PE0701 | Decision of registration |
Patent event code: PE07011S01D Comment text: Decision to Grant Registration Patent event date: 20240809 |
|
| GRNT | Written decision to grant | ||
| PR0701 | Registration of establishment |
Comment text: Registration of Establishment Patent event date: 20240812 Patent event code: PR07011E01D |
|
| PR1002 | Payment of registration fee |
Payment date: 20240812 End annual number: 3 Start annual number: 1 |
|
| PG1601 | Publication of registration |