WO1995018994A1 - Korrekturverfahren zwischen dem elektrischen phasenwinkel und dem mechanischen abtriebswinkel eines schrittmotors - Google Patents
Korrekturverfahren zwischen dem elektrischen phasenwinkel und dem mechanischen abtriebswinkel eines schrittmotors Download PDFInfo
- Publication number
- WO1995018994A1 WO1995018994A1 PCT/DE1994/000606 DE9400606W WO9518994A1 WO 1995018994 A1 WO1995018994 A1 WO 1995018994A1 DE 9400606 W DE9400606 W DE 9400606W WO 9518994 A1 WO9518994 A1 WO 9518994A1
- Authority
- WO
- WIPO (PCT)
- Prior art keywords
- stepper motor
- angle
- encoder
- control
- coefficients
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Ceased
Links
Classifications
-
- G—PHYSICS
- G01—MEASURING; TESTING
- G01R—MEASURING ELECTRIC VARIABLES; MEASURING MAGNETIC VARIABLES
- G01R7/00—Instruments capable of converting two or more currents or voltages into a single mechanical displacement
- G01R7/04—Instruments capable of converting two or more currents or voltages into a single mechanical displacement for forming a quotient
- G01R7/06—Instruments capable of converting two or more currents or voltages into a single mechanical displacement for forming a quotient moving-iron type
-
- H—ELECTRICITY
- H02—GENERATION; CONVERSION OR DISTRIBUTION OF ELECTRIC POWER
- H02P—CONTROL OR REGULATION OF ELECTRIC MOTORS, ELECTRIC GENERATORS OR DYNAMO-ELECTRIC CONVERTERS; CONTROLLING TRANSFORMERS, REACTORS OR CHOKE COILS
- H02P8/00—Arrangements for controlling dynamo-electric motors rotating step by step
- H02P8/22—Control of step size; Intermediate stepping, e.g. microstepping
-
- G—PHYSICS
- G05—CONTROLLING; REGULATING
- G05B—CONTROL OR REGULATING SYSTEMS IN GENERAL; FUNCTIONAL ELEMENTS OF SUCH SYSTEMS; MONITORING OR TESTING ARRANGEMENTS FOR SUCH SYSTEMS OR ELEMENTS
- G05B2219/00—Program-control systems
- G05B2219/30—Nc systems
- G05B2219/34—Director, elements to supervisory
- G05B2219/34048—Fourier transformation, analysis, fft
-
- G—PHYSICS
- G05—CONTROLLING; REGULATING
- G05B—CONTROL OR REGULATING SYSTEMS IN GENERAL; FUNCTIONAL ELEMENTS OF SUCH SYSTEMS; MONITORING OR TESTING ARRANGEMENTS FOR SUCH SYSTEMS OR ELEMENTS
- G05B2219/00—Program-control systems
- G05B2219/30—Nc systems
- G05B2219/41—Servomotor, servo controller till figures
- G05B2219/41176—Compensation control, position error with data from lookup memory
-
- G—PHYSICS
- G05—CONTROLLING; REGULATING
- G05B—CONTROL OR REGULATING SYSTEMS IN GENERAL; FUNCTIONAL ELEMENTS OF SUCH SYSTEMS; MONITORING OR TESTING ARRANGEMENTS FOR SUCH SYSTEMS OR ELEMENTS
- G05B2219/00—Program-control systems
- G05B2219/30—Nc systems
- G05B2219/41—Servomotor, servo controller till figures
- G05B2219/41326—Step motor
Definitions
- rotary magnet quotient measuring units In addition to mechanical tachometers, bimetallic instruments and moving coil instruments, rotary magnet quotient measuring units (DQM) have mainly been used to drive pointer instruments, especially in vehicles. In recent times, however - especially in Europe - stepper motors (2-phase) as pointer drives are becoming more and more popular. Such stepper motors are used both as direct drives (NMB) and - preferably - as geared motors (manufacturers switec and VDO).
- NMB direct drives
- VDO geared motors
- claw-pole (tin-can) stepper motors For direct drives, only claw-pole (tin-can) stepper motors have been used for torque and cost reasons.
- Sinus drive have acceptable synchronism properties.
- these motors have poorer mechanical characteristics than the corresponding ones with increased design effort
- additional sensors e.g. B. a Hall IC.
- Control pulses a particularly simple encoder (digital
- Angle encoder from the 'lowest cost' range can be used and therefore does not cost much more than a zero sensor that detects the zero position of the stepper motor.
- the motion control of the stepper motor can thus also be detected and, above all, used to correct the microstep behavior, the resolution required being far below that required in conventional control methods. This enables the
- Stepper motor for example, with a resolution of 0.1 °
- FIG. 1 shows a first block diagram according to the prior art
- FIG. 2 shows a first diagram
- FIG. 3 shows a second diagram
- FIG. 4 shows a second block diagram
- FIG. 5 shows a third block diagram
- FIGS. 6a and b each show a second diagram
- Figure 7 shows a fourth block diagram
- Figure 8 shows a fifth block diagram
- Figure 9 shows a third
- FIG. 10 shows a fourth diagram and FIG. 11 a fifth diagram.
- the first block diagram according to FIG. 1 shows a known one
- Stepper motor 3 on whose shaft an encoder or angle encoder 4 is fixed.
- the angle encoder 4 has a fixed one
- a pointer 8 for a display instrument is attached to the shaft, that of a fixed one
- Dial 5 is assigned.
- the display instrument can be installed in an instrument panel of a motor vehicle.
- Stepper motor 3 is supplied by an output stage 2 with current pulses which are generated by an upstream controller 1.
- the known controller 1 compares a setpoint 11 with the value measured by the angle transmitter 4 at a point 10 and thus controls or regulates the current for the output stage 2.
- Figure 2 shows a first diagram in which the difference
- Figure 3 shows a second diagram in which a measured
- Characteristic curve 31 is compared, which is based on the four
- Figure 4 shows as a first embodiment of the invention, a second block diagram for the stepper motor 3, in which the
- Control has a correction level 40.
- the Fourier coefficients determined are in the correction stage 40 after the simplified one
- Figure 5 shows a third block diagram in which the
- Coefficient adjustment 41 is supplemented.
- the signals of the angle encoder 4 are compared with setpoints 11.
- Figure 6Q shows a second diagram in which the formation of
- the top curve corresponds to the Angle division on code disc 7 of the angle encoder 4.
- Angle encoder 4 emits ideal or real signals that correspond to the two curves shown below. In the next curve, the measured signals of the angle encoder 4
- the method according to the invention is based on the assumption that a simple (possibly single-channel) encoder (digital angle encoder) does not cause very much more costs than a conventional zero sensor. However, in addition to zeroing, it can also be used for motion control (self-diagnosis) and, above all, for correcting the microstep behavior, the resolution required being far below that required for classic control methods (basic structure corresponding to FIG. 1).
- the present invention corresponds to method C. According to previous experience with stepper motor direct drives, the periodic non-linearities dominate over all others
- An exemplary embodiment proves that the error of an individual drive can be described with sufficient accuracy with only 4 to 5 Fourier coefficients, so that only a very small one
- RAM Memory requirement
- An exemplary embodiment proves that the error of an individual drive can be described with sufficient accuracy with only 4 to 5 Fourier coefficients, so that only a very small one
- RAM Memory requirement
- Inexpensive preferably only once in the test facility.
- the disadvantage is that drifts in the actual coefficients (temperature, supply voltage, aging) cannot be recorded.
- At least one simple encoder required (Fig. 5).
- the system is then able to adjust the coefficients itself, for which a maximum of one pointer revolution is required in practice. All drifts of the periodic disturbances are then continuously recorded and the correction coefficients are adapted accordingly; this results in an optimal correction over the lifetime.
- a certain self-diagnosis of the system is advantageously possible by evaluating the constantly recorded deviations.
- the encoder can also be used for the detection of the zero point, e.g. B. in connection with a stop.
- stepper motor described has a certain hysteresis due to the principle, typically about 1 °. This hysteresis can occur in both Correction principles are taken into account, with possible overcompensation in classic control leading to extremely unsteady pointer movements. With adaptive control, the
- Hysteresis is constantly measured and corrected accordingly.
- Hysteresis - simulated by a simple mathematical model.
- Microcontroller programmed and in connection with a
- Pulse width modulation is used to control the stepper motor.
- PWM control Pulse width modulation
- the adaptive component can be deactivated at high angular speeds. On the one hand, this saves computing time, which becomes increasingly critical with increasing angular velocity; on the other hand, the validity of the static correction characteristic curve is no longer adequately maintained at high angular speeds.
- Component can also be deactivated because the
- This method can be modified in such a way that a correction value for the edges is determined from the average length of the high or low periods of the encoder signal and is taken into account in each case in the evaluation (FIG. 6b).
- Stepper motor as well as that of the encoder calculated.
- the controlled system with the transfer function F consists here of the stepper motor 3 with the control 2 and the mechanical system of shaft, pointer 8 and code disc 6 (cf.
- angles are in units of the mechanical angle
- Control F s -1 is a sufficiently smoothed function, that is to say that random errors are averaged out, since otherwise the pointer movement becomes unnecessarily restless (FIG. 8). To meet these conditions, the Fourier transform of the angular deviation according to FIG. 12 is calculated. Since the period of the fundamental and the harmonics is known, this is sufficient
- the amplitude is shown in FIG. 9 for illustration
- the UF exists (uniqueness), but cannot analytically. be determined.
- An approximate solution could e.g. B. can be calculated using iterative methods.
- control value Given a given value, the control value can be increased to
- the coefficients a k , b k can be controlled by sensor data (e.g.
- Temperature sensors which may be present anyway.
- Proposal 2 corresponds to the present invention according to FIG. 5, which shows the control engineering structure (FIG. 8). Various aspects must be taken into account during implementation:
- n the index of the
- the pointer movement is then identical to that when the original method was carried out, in which the error curve was initially sampled and Fourier-transformed, and thus the adaptation method could only take effect when the values were corrected.
- Dynamic range is usable. If the engine is operated in a higher dynamic range, the dynamic moments increasingly influence the engine behavior and must therefore no longer be disregarded. The adaptive part of the procedure should therefore be shut down for this area.
Landscapes
- Engineering & Computer Science (AREA)
- Power Engineering (AREA)
- Physics & Mathematics (AREA)
- General Physics & Mathematics (AREA)
- Control Of Stepping Motors (AREA)
- Transmission And Conversion Of Sensor Element Output (AREA)
- Spectrometry And Color Measurement (AREA)
Abstract
Description


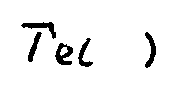


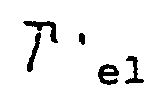


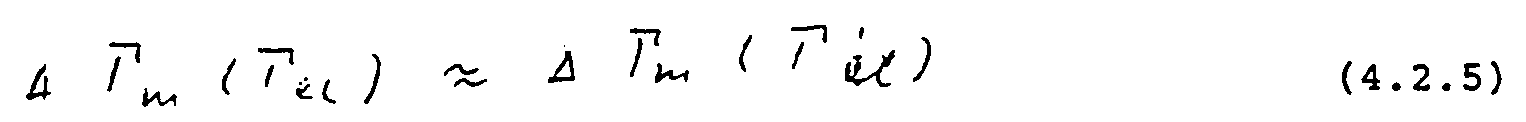


Claims




Priority Applications (5)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| JP7518253A JPH09506759A (ja) | 1994-01-11 | 1994-05-28 | ステップモータの電気位相角と機械的駆動角との間の補正方法 |
| EP94916140A EP0739501B1 (de) | 1994-01-11 | 1994-05-28 | Korrekturverfahren zwischen dem elektrischen phasenwinkel und dem mechanischen abtriebswinkel eines schrittmotors |
| US08/669,341 US5847475A (en) | 1994-01-11 | 1994-05-28 | Method of correction between electrical phase angle and mechanical output angle of stepper motor |
| DE59407196T DE59407196D1 (de) | 1994-01-11 | 1994-05-28 | Korrekturverfahren zwischen dem elektrischen phasenwinkel und dem mechanischen abtriebswinkel eines schrittmotors |
| AU67931/94A AU6793194A (en) | 1994-01-11 | 1994-05-28 | Correction process between the electric phase angle and mechanical output angle of a step motor |
Applications Claiming Priority (2)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| DE4400482A DE4400482A1 (de) | 1993-04-23 | 1994-01-11 | Korrekturverfahren zwischen dem elektrischen Phasenwinkel und dem mechanischen Abtriebswinkel eines Schrittmotors |
| DEP4400482.6 | 1994-01-11 |
Publications (1)
| Publication Number | Publication Date |
|---|---|
| WO1995018994A1 true WO1995018994A1 (de) | 1995-07-13 |
Family
ID=6507660
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| PCT/DE1994/000606 Ceased WO1995018994A1 (de) | 1994-01-11 | 1994-05-28 | Korrekturverfahren zwischen dem elektrischen phasenwinkel und dem mechanischen abtriebswinkel eines schrittmotors |
Country Status (7)
| Country | Link |
|---|---|
| US (1) | US5847475A (de) |
| EP (1) | EP0739501B1 (de) |
| JP (1) | JPH09506759A (de) |
| AU (1) | AU6793194A (de) |
| CZ (1) | CZ9602002A3 (de) |
| ES (1) | ES2124407T3 (de) |
| WO (1) | WO1995018994A1 (de) |
Families Citing this family (19)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| US6380658B1 (en) * | 1999-07-15 | 2002-04-30 | Delphi Technologies Inc. | Method and apparatus for torque ripple reduction in sinusoidally excited brushless permanent magnet motors |
| US6191549B1 (en) * | 1999-08-03 | 2001-02-20 | Honeywell International Inc. | Apparatus and method for producing high fidelity output with a limited resolution output device |
| US6498453B1 (en) * | 2000-11-01 | 2002-12-24 | Delphi Technologies, Inc. | Two-phase stepping motor gauge control system |
| KR20060005403A (ko) | 2003-04-28 | 2006-01-17 | 나노머슬, 인크. | 일체로 형성된 형상 기억 합금 액츄에이터를 갖는 유동제어 조립체 |
| KR20060041164A (ko) * | 2003-05-02 | 2006-05-11 | 알프마이어 프레치지온 악티엔게젤샤프트 바우그룹펜 운트 지스템뢰중엔 | 일체형 형상 기억 합금 액츄에이터를 갖는 게이지 포인터 |
| EP1664604B3 (de) | 2003-09-05 | 2020-09-23 | Alfmeier Präzision SE | System, verfahren und vorrichtung zur verringerung von reibungskräften und zum ausgleich von gedächtnislegierungsbetätigten ventilen und -ventilsystemen bei hohen temperaturen |
| JP4387750B2 (ja) * | 2003-10-06 | 2009-12-24 | 矢崎総業株式会社 | 指示位置補正方法及びその装置、並びに、指示装置 |
| US7145309B2 (en) * | 2004-09-14 | 2006-12-05 | Freescale Semiconductor, Inc. | Open loop motor parking method and system |
| US7863851B2 (en) * | 2007-08-22 | 2011-01-04 | National Instruments Corporation | Closed loop stepper motor control |
| JP5111031B2 (ja) | 2007-09-14 | 2012-12-26 | キヤノン株式会社 | 変位検出方法及びモータ制御装置 |
| JP2009077467A (ja) * | 2007-09-19 | 2009-04-09 | Furuno Electric Co Ltd | ステッピングモータのマイクロステップ駆動方法およびそれを用いた指示装置 |
| KR101410461B1 (ko) * | 2007-12-27 | 2014-06-30 | 삼성전자주식회사 | 계기장치의 영점위치조절방법 및 이를 이용하는 냉장고의온도표시방법 |
| FR2941296A1 (fr) * | 2009-01-22 | 2010-07-23 | Johnson Controls Tech Co | Procede de calibration et/ou de correction d'un dispositif d'affichage ayant une aiguille, l'aiguille etant mobile en rotation autour d'un axe de rotation |
| US8219348B2 (en) * | 2009-01-22 | 2012-07-10 | Johnson Controls Technology Company | Method for calibrating and/or correcting a display device having a needle, the needle being able to move in rotation about an axis of rotation |
| FR2941295B1 (fr) * | 2009-01-22 | 2015-04-24 | Johnson Controls Tech Co | Procede de calibration et/ou de correction d'un dispositif d'affichage ayant une aiguille, l'aiguille etant mobile en rotation autour d'un axe de rotation |
| JP5848962B2 (ja) * | 2011-11-24 | 2016-01-27 | オークマ株式会社 | 位置制御装置 |
| CN102843082B (zh) * | 2012-09-06 | 2014-12-24 | 山东省科学院自动化研究所 | 一种步进电机式汽车仪表指针自适应控制算法 |
| US9970792B2 (en) * | 2014-08-11 | 2018-05-15 | Continental Automotive Systems, Inc. | Stepper motor assembly having opposite shafts |
| DE102016214456A1 (de) * | 2016-08-04 | 2018-02-08 | Dr. Johannes Heidenhain Gesellschaft Mit Beschränkter Haftung | Positionsmesseinrichtung und Verfahren zum Betreiben einer Positionsmesseinrichtung |
Citations (9)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| DE2850539A1 (de) * | 1978-11-22 | 1980-05-29 | Strahlen Umweltforsch Gmbh | Verfahren und schaltungsanordnung zur steuerung eines elektrischen schrittmotors |
| JPS6085474A (ja) * | 1983-10-18 | 1985-05-14 | Hitachi Ltd | 磁気記録再生装置のヘツド位置決め装置 |
| EP0189794A2 (de) * | 1985-01-30 | 1986-08-06 | International Business Machines Corporation | Elektromagnetisches Antriebsystem |
| SU1267360A1 (ru) * | 1985-02-20 | 1986-10-30 | Ордена Трудового Красного Знамени Институт Сверхтвердых Материалов Ан Усср | Устройство дл программного управлени позиционированием |
| JPS6369497A (ja) * | 1986-09-10 | 1988-03-29 | Matsushita Electric Ind Co Ltd | 位置決め装置 |
| JPH02179298A (ja) * | 1988-12-27 | 1990-07-12 | Matsushita Electric Ind Co Ltd | 位置制御装置 |
| WO1991007009A1 (en) * | 1989-10-26 | 1991-05-16 | Siemens Aktiengesellschaft | Parametric current control for microstepping unipolar motor |
| JPH04201059A (ja) * | 1990-11-29 | 1992-07-22 | Nissan Motor Co Ltd | カム研削盤 |
| EP0571759A2 (de) * | 1992-05-27 | 1993-12-01 | Robert Bosch Gmbh | Kontrollierte Mikroschrittsteuerung für einen Schrittmotor |
Family Cites Families (1)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| US4584512A (en) * | 1980-02-27 | 1986-04-22 | Pritchard Eric K | Microstepping drives with waveform tuning and microprocessor control |
-
1994
- 1994-05-28 EP EP94916140A patent/EP0739501B1/de not_active Expired - Lifetime
- 1994-05-28 JP JP7518253A patent/JPH09506759A/ja active Pending
- 1994-05-28 AU AU67931/94A patent/AU6793194A/en not_active Abandoned
- 1994-05-28 CZ CZ962002A patent/CZ9602002A3/cs unknown
- 1994-05-28 ES ES94916140T patent/ES2124407T3/es not_active Expired - Lifetime
- 1994-05-28 US US08/669,341 patent/US5847475A/en not_active Expired - Fee Related
- 1994-05-28 WO PCT/DE1994/000606 patent/WO1995018994A1/de not_active Ceased
Patent Citations (9)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| DE2850539A1 (de) * | 1978-11-22 | 1980-05-29 | Strahlen Umweltforsch Gmbh | Verfahren und schaltungsanordnung zur steuerung eines elektrischen schrittmotors |
| JPS6085474A (ja) * | 1983-10-18 | 1985-05-14 | Hitachi Ltd | 磁気記録再生装置のヘツド位置決め装置 |
| EP0189794A2 (de) * | 1985-01-30 | 1986-08-06 | International Business Machines Corporation | Elektromagnetisches Antriebsystem |
| SU1267360A1 (ru) * | 1985-02-20 | 1986-10-30 | Ордена Трудового Красного Знамени Институт Сверхтвердых Материалов Ан Усср | Устройство дл программного управлени позиционированием |
| JPS6369497A (ja) * | 1986-09-10 | 1988-03-29 | Matsushita Electric Ind Co Ltd | 位置決め装置 |
| JPH02179298A (ja) * | 1988-12-27 | 1990-07-12 | Matsushita Electric Ind Co Ltd | 位置制御装置 |
| WO1991007009A1 (en) * | 1989-10-26 | 1991-05-16 | Siemens Aktiengesellschaft | Parametric current control for microstepping unipolar motor |
| JPH04201059A (ja) * | 1990-11-29 | 1992-07-22 | Nissan Motor Co Ltd | カム研削盤 |
| EP0571759A2 (de) * | 1992-05-27 | 1993-12-01 | Robert Bosch Gmbh | Kontrollierte Mikroschrittsteuerung für einen Schrittmotor |
Non-Patent Citations (5)
| Title |
|---|
| PATENT ABSTRACTS OF JAPAN vol. 12, no. 293 (E - 645) 10 August 1988 (1988-08-10) * |
| PATENT ABSTRACTS OF JAPAN vol. 14, no. 451 (E - 0984) 27 September 1990 (1990-09-27) * |
| PATENT ABSTRACTS OF JAPAN vol. 16, no. 534 (M - 1334) 4 November 1992 (1992-11-04) * |
| PATENT ABSTRACTS OF JAPAN vol. 9, no. 227 (P - 388) 13 September 1985 (1985-09-13) * |
| SOVIET PATENTS ABSTRACTS Section EI Week 8724, 24 June 1987 Derwent World Patents Index; Class T06, AN 87-169510 * |
Also Published As
| Publication number | Publication date |
|---|---|
| CZ9602002A3 (en) | 1997-03-12 |
| AU6793194A (en) | 1995-08-01 |
| EP0739501A1 (de) | 1996-10-30 |
| US5847475A (en) | 1998-12-08 |
| JPH09506759A (ja) | 1997-06-30 |
| ES2124407T3 (es) | 1999-02-01 |
| EP0739501B1 (de) | 1998-10-28 |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| EP0739501B1 (de) | Korrekturverfahren zwischen dem elektrischen phasenwinkel und dem mechanischen abtriebswinkel eines schrittmotors | |
| EP2646836B1 (de) | Verfahren zur bestimmung der drehzahl einer synchronmaschine | |
| EP2577026B1 (de) | Verfahren und Computerprogrammprodukt zum Kalibrieren eines Stellgebersystems | |
| DE102008006983A1 (de) | Verfahren zur Ermittlung eines Korrekturwertes für die Winkellage des Rotors eines elektrisch kommutierten reversierbaren Synchron-Motors | |
| EP3288179A1 (de) | Verfahren zur sensorlosen bestimmung der orientierung des rotors eines eisenlosen pmsm motors | |
| DE4400482A1 (de) | Korrekturverfahren zwischen dem elektrischen Phasenwinkel und dem mechanischen Abtriebswinkel eines Schrittmotors | |
| DE19700457C1 (de) | Vorrichtung und Verfahren für eine Scheibenwischanlage | |
| DE102014101604A1 (de) | System und Verfahren zum Steuern eines bürstenlosen Gleichstromelektromotors mit sinusförmigem Antrieb für einen elektrischen Kraftfahrzeugaktuator | |
| WO2013092398A2 (de) | Verfahren und vorrichtung zum korrigieren eines messwertes eines drehwinkels eines rotors einer elektrischen maschine | |
| DE69708835T2 (de) | Vorrichtung zur steuerung eines schrittmotors in einem messinstrument | |
| EP1872466A1 (de) | Verfahren zur sensorlosen positionserfassung eines rotors eines elektromotors | |
| DE102012111799A1 (de) | Elektrisch kommutierter Motor und Verfahren zum Kalibieren eines elektrisch kommutierten Motors | |
| EP0593523B1 (de) | Verfahren zum betrieb eines drehzahlregelbaren motors | |
| DE69318973T2 (de) | Vorrichtung zur korrektur des pendelns bei hysterese-synchronmotoren | |
| EP3464862B1 (de) | Verfahren und vorrichtung zur kalibrierung eines stellgebersystems | |
| DE102008002339A1 (de) | Erregungszeitpunkt-Bestimmungsschaltung und Bestimmungsverfahren für einen Erregungszeitpunkt eines Motors | |
| EP2286183B1 (de) | Verfahren zum betreiben eines mit wenigstens einem schrittmotor angetriebenen anzeigegeräts | |
| DE102016122105A1 (de) | Verfahren zur Verringerung von Gleichlaufschwankungen eines Permanentmagneterregten Elektromotors | |
| DE60130190T2 (de) | Motorsteuerung mit Informationsvisualisierung | |
| DE19747410A1 (de) | Verfahren zur Synchronisierung von Elektro-Motorischer-Kraft und Stromraumzeiger bei digital feldorientiert geregelten Synchronantrieben | |
| EP4318930B1 (de) | Verfahren und vorrichtung zur bereitstellung eines kommutierungsintervalls | |
| DE112022007978T5 (de) | Rotorpositionskalibrierungsverfahren und -Vorrichtung und Speichermedium | |
| DE19920968A1 (de) | Anordnung und Meßverfahren zur Erfassung von wenigstens einer bewegungscharakteristischen Größe eines bewegten Meßgerätekörpers | |
| DE19928357A1 (de) | Verfahren zum Betreiben einer Synchronmaschine sowie elektrischer Antrieb | |
| DE102021203222A1 (de) | Verfahren und Vorrichtung zur Bereitstellung eines Kommutierungsintervalls |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| AK | Designated states |
Kind code of ref document: A1 Designated state(s): AU CZ JP KR US |
|
| AL | Designated countries for regional patents |
Kind code of ref document: A1 Designated state(s): AT BE CH DE DK ES FR GB GR IE IT LU MC NL PT SE |
|
| DFPE | Request for preliminary examination filed prior to expiration of 19th month from priority date (pct application filed before 20040101) | ||
| 121 | Ep: the epo has been informed by wipo that ep was designated in this application | ||
| WWE | Wipo information: entry into national phase |
Ref document number: 1994916140 Country of ref document: EP |
|
| WWE | Wipo information: entry into national phase |
Ref document number: 08669341 Country of ref document: US |
|
| WWE | Wipo information: entry into national phase |
Ref document number: PV1996-2002 Country of ref document: CZ |
|
| WWP | Wipo information: published in national office |
Ref document number: 1994916140 Country of ref document: EP |
|
| WWP | Wipo information: published in national office |
Ref document number: PV1996-2002 Country of ref document: CZ |
|
| WWG | Wipo information: grant in national office |
Ref document number: 1994916140 Country of ref document: EP |
|
| WWR | Wipo information: refused in national office |
Ref document number: PV1996-2002 Country of ref document: CZ |