WO2020090864A1 - Dispositif de commande d'angle de volant de direction - Google Patents
Dispositif de commande d'angle de volant de direction Download PDFInfo
- Publication number
- WO2020090864A1 WO2020090864A1 PCT/JP2019/042505 JP2019042505W WO2020090864A1 WO 2020090864 A1 WO2020090864 A1 WO 2020090864A1 JP 2019042505 W JP2019042505 W JP 2019042505W WO 2020090864 A1 WO2020090864 A1 WO 2020090864A1
- Authority
- WO
- WIPO (PCT)
- Prior art keywords
- angle
- angular velocity
- steering
- steering wheel
- motor
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Ceased
Links
Images



Classifications
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B62—LAND VEHICLES FOR TRAVELLING OTHERWISE THAN ON RAILS
- B62D—MOTOR VEHICLES; TRAILERS
- B62D6/00—Arrangements for automatically controlling steering depending on driving conditions sensed and responded to, e.g. control circuits
-
- A—HUMAN NECESSITIES
- A01—AGRICULTURE; FORESTRY; ANIMAL HUSBANDRY; HUNTING; TRAPPING; FISHING
- A01B—SOIL WORKING IN AGRICULTURE OR FORESTRY; PARTS, DETAILS, OR ACCESSORIES OF AGRICULTURAL MACHINES OR IMPLEMENTS, IN GENERAL
- A01B69/00—Steering of agricultural machines or implements; Guiding agricultural machines or implements on a desired track
- A01B69/007—Steering or guiding of agricultural vehicles, e.g. steering of the tractor to keep the plough in the furrow
- A01B69/008—Steering or guiding of agricultural vehicles, e.g. steering of the tractor to keep the plough in the furrow automatic
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B62—LAND VEHICLES FOR TRAVELLING OTHERWISE THAN ON RAILS
- B62D—MOTOR VEHICLES; TRAILERS
- B62D15/00—Steering not otherwise provided for
- B62D15/02—Steering position indicators ; Steering position determination; Steering aids
- B62D15/021—Determination of steering angle
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B62—LAND VEHICLES FOR TRAVELLING OTHERWISE THAN ON RAILS
- B62D—MOTOR VEHICLES; TRAILERS
- B62D5/00—Power-assisted or power-driven steering
- B62D5/04—Power-assisted or power-driven steering electrical, e.g. using an electric servo-motor connected to, or forming part of, the steering gear
Definitions
- the embodiment of the present invention relates to a technique for controlling a steering wheel angle of a vehicle.
- Target vehicles to be subjected to such automatic steering include those equipped with a mechanism corresponding to the automatic steering and those for a manual vehicle equipped only with a mechanism that does not correspond to the automatic steering and manually operates the steering wheel. ..
- the steering handle for rotating the input shaft that inputs the rotational force as the steering torque to the steering system and performing the manual steering can be removed from the input shaft. Therefore, a steering drive device that drives the input shaft to rotate at a predetermined steering wheel angle is incorporated between the input shaft and the steering handle, and by controlling this steering drive device, it is possible to make a manual vehicle compatible with automatic steering. Becomes
- a vehicle guidance system including a drive assembly that generates torque around a drive shaft that is coaxial with a steering wheel that drives the drive mechanism and directly drives the steering assembly in response to a steering control signal (for example, Patent Document 1). reference).
- the work vehicle travels along a predetermined travel route.
- the work vehicle is driven.
- the person must recognize the obstacle and perform the operation of releasing the automatic steering function, and then manually operate the handle to avoid the obstacle. That is, in the conventional automatic steering of the work vehicle, there is a problem that an operation for canceling the automatic steering function is required in advance in order to avoid an obstacle or a person during the automatic steering.
- the present invention has been made to solve the above-described problems, and an object of the present invention is to provide a steering wheel angle control device that can be switched to a manual operation without performing an operation to cancel the automatic steering function.
- the steering wheel angle control device of the present embodiment includes a motor that drives an input shaft that gives a declination angle to wheels of a vehicle and inputs a steering wheel angle that is a rotation angle to a steering system of the vehicle,
- a measurement angle acquisition unit that acquires the measurement angle from a sensor, an angular velocity output unit that outputs an angular velocity to the motor as an instruction angular velocity, an angular velocity calculation unit that calculates an angular velocity based on the acquired measurement angle as a measurement angular velocity, and An angular velocity determination unit that determines whether or not an absolute value of a difference between the indicated angular velocity and the measured angular velocity is equal to or greater than a first threshold value set in advance, and the angular velocity output unit , If the absolute value of the difference is determined to more than the first threshold value, characterized in that it stops the control of the motor.
- FIG. 1 is a schematic side view showing the configuration of the agricultural tractor according to the embodiment.
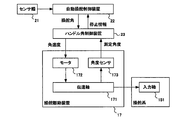
- FIG. 2 is a block diagram showing the hardware configuration of the automatic steering system according to the embodiment.
- the vehicle to be steered by the automatic steering system is a working vehicle, and specifically, the agricultural tractor 1 as shown in FIG.
- the tractor 1 is a four-wheel vehicle including a vehicle body 10, two front wheels 11 and two rear wheels 12, but any vehicle that can be steered may be used. Further, the tractor 1 includes a seat 13 for a driver to sit on, a link mechanism 14 for connecting and connecting a work machine (not shown), a steering column 15, a steering handle 16, a steering drive device 17, pedals 18 including an accelerator, a brake, and the like.
- a roof portion 19 is provided.
- a steering system for steering the tractor 1 by giving a deflection angle to the front wheels 11 in the steering column 15 is provided, and an input shaft for inputting the steering wheel angle by the steering handle 16 or the steering drive device 17 to the steering system.
- 151 is built in, and a steering angle based on the rotation of the input shaft 151 is given to the front wheels 11.
- the steering drive device 17 is a device that is not provided with a configuration for performing automatic steering control and is attached later to automatically steer the tractor 1 that is premised on manual steering.
- the upper end of the input shaft 151 of the steering system is fitted below.
- the roof portion 19 is a substantially flat plate member placed as a whole on four support frames provided at different positions in the front, rear, left, and right of the vehicle body 10.
- a sensor 21 including at least a GNSS (Global Navigation Satellite System) and a gyro sensor is provided on the upper surface of the roof portion 19.
- the sensors 21 may include any sensors as long as they detect at least the position of the vehicle and the orientation of the vehicle on the traveling surface.
- An automatic steering control device 22 that controls the automatic steering of the tractor 1 is provided on one of the support frames that supports the roof portion 19 and that is located in the front.
- the automatic steering system includes a steering drive device 17 for driving an input shaft 151 in a steering system, sensors 21, an automatic steering control device 22, and a steering wheel angle control device 23 not shown in FIG. It is composed of
- the steering drive device 17 includes a transmission shaft 171 that transmits a driving force to the input shaft 151, a motor 172 that is a stepping motor that drives the transmission shaft 171, and an angle sensor that is a rotary encoder that detects a rotation angle of the transmission shaft 171 as a handle angle. 173 is provided.
- the motor 172 may be any type of motor as long as it can output a torque sufficient to rotate the input shaft 151.
- the automatic steering control device 22 outputs the steering angle based on the detection value of the sensors 21, and the steering wheel angle control device 23 feedback controls the steering drive device 17 based on the steering angle instructed by the automatic steering control device 22.
- the steering drive device 17 drives the transmission shaft 171 by controlling the motor 172 with the target angle being the steering wheel angle at which the rotational position detected by the angle sensor 173 becomes the desired rotational position.
- the automatic steering control device 22 is provided with a display as an input / output device for presenting information related to automatic steering to the driver and acquiring an operation from the driver.
- the tractor 1 configured to be manually steered by installing the steering drive device 17, the sensors 21, the automatic steering control device 22, and the steering wheel angle control device 23 to the tractor 1 afterwards. It is possible to realize automatic steering.
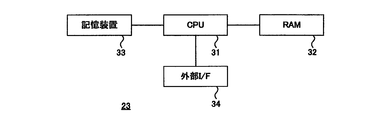
- the steering wheel angle control device 23 includes, as hardware, a CPU (Central Processing Unit) 31, a RAM (Random Access Memory) 32, a storage device 33, and an external I / F (Interface) 34.
- a CPU Central Processing Unit
- RAM Random Access Memory
- storage device 33 a storage device
- I / F Interface
- the CPU 31 and the RAM 32 cooperate to execute various functions described later, and the storage device 33 stores various data used for processing executed by the various functions.
- the external I / F 34 inputs / outputs data to / from the automatic steering control device 22, the motor 172, and the angle sensor 173 as external devices.
- the steering wheel angle control device 23 has a target angle calculation unit 231, a measurement angle acquisition unit 232, an angular velocity output unit 233, an angular velocity calculation unit 234, a smoothing processing unit 235, and an angular velocity determination unit. 236 and a presentation unit 237 are provided.
- the target angle calculation unit 231 calculates a steering wheel angle as a target angle based on the target steering angle output by the automatic steering control device 22.
- the measurement angle acquisition unit 232 acquires the steering wheel angle measured by the angle sensor 173 as the measurement angle.
- the angular velocity output unit 233 outputs, to the motor 172, an angular velocity that reduces the deviation angle between the target angle and the measurement angle as the instruction angular velocity.
- the measured angle acquired by the measured angle acquisition unit 232 and the indicated angular velocity output by the angular velocity output unit 233 are stored in the storage device 33 in time series.
- the angular velocity calculation unit 234 calculates the angular velocity based on the measurement angle acquired by the measurement angle acquisition unit 232 as the measurement angular velocity. This measured angular velocity is also stored in the storage device 33 in time series, like the measured angle and the indicated angular velocity.
- the smoothing processing unit 235 smoothes the angular velocity calculated by the angular velocity calculation unit 234.
- the angular velocity determination unit 236 normally controls the rotation angle of the transmission shaft 171, and thus the input shaft 151, based on the angular velocity output by the angular velocity output unit 233 and the angular velocity smoothed by the smoothing processing unit 235. It is determined whether it has been done.
- the steering angle control When the presenting unit 237 determines by the angular velocity determining unit 236 that the rotation angle of the transmission shaft 171 is not normally controlled, the steering angle control, and thus the automatic steering, is stopped for the automatic steering control device 22.
- the driver is notified that the automatic steering has been stopped by notifying the automatic steering control device 22 of stop information indicating that the automatic steering has been stopped.
- this presentation is made by the display provided in the automatic steering control device 22, but any means may be used.
- FIG. 5 is a flowchart showing the steering wheel angle determination process.
- the steering wheel angle is assumed to be controlled in every predetermined cycle, and the steering wheel angle determination process shown in FIG. And
- the angular velocity calculation unit 234 calculates the angular velocity of the transmission shaft 171 and thus the input shaft 151 as the measured angular velocity based on the measurement angle acquired by the measurement angle acquisition unit 232 (S101). ..
- the angular velocity calculation unit 234 calculates the current measurement angular velocity by differentiating a plurality of measurement angles including the latest measurement angle among the measurement angles stored in the storage device 33. Further, the calculated measured angular velocities are stored in the storage device 33 in time series.
- the smoothing processing unit 235 smoothes the measured angular velocity (S102).
- the smoothing processing unit 235 smoothes the measurement angular velocity by calculating a moving average of the plurality of measurement angular velocities including the current measurement angular velocity, and calculates the current smoothed measurement angular velocity. Skips and noise in the angular velocity are removed.
- the angular velocity determination unit 236 determines whether or not the absolute value of the difference between the current designated angular velocity and the current smoothed measured angular velocity is equal to or greater than a first threshold value that is a preset value ( S103).
- the angular velocity determination unit 236 determines that the excess time, which is the time during which the absolute value of the difference is determined to be greater than or equal to the first threshold value, continuously, It is determined whether or not it is equal to or more than a second threshold value which is a preset time (S104).
- the angular velocity output unit 233 stops the output of the angular velocity to the motor 172 to stop the control of the motor 172 (S105), and the presentation unit 237 controls the automatic steering.
- the driver is instructed to stop the steering wheel angle control, and thus the automatic steering control (S106).
- step S103 when the absolute value of the difference is not equal to or larger than the first threshold value (S103, NO), the operation of the current cycle of the steering wheel angle determination processing is ended.
- the steering wheel angle control device 23 of the present embodiment it is possible to perform determination based on the difference between the instruction angular velocity output to the motor 172 and the measurement angular velocity based on the measurement angle acquired from the angle sensor 173. Based on this, the steering wheel angle control and eventually the automatic steering control are stopped. As a result, when the driver operates the steering handle 16 to avoid an obstacle that blocks the course of the tractor 1 during automatic steering control, the automatic steering control is stopped and switched to manual steering. It is not necessary to cancel the operation.
- the separation between the indicated angular velocity and the measured angular velocity may occur due to a failure of a mechanism inside the steering drive device 17 or a motor 172. Therefore, when the steering handle 16 is not operated, the steering drive device 17 fails to control the steering wheel angle. Since the automatic steering control is stopped and the driver is notified of that, the tractor 1 can be operated more safely.
Landscapes
- Engineering & Computer Science (AREA)
- Mechanical Engineering (AREA)
- Chemical & Material Sciences (AREA)
- Combustion & Propulsion (AREA)
- Transportation (AREA)
- Life Sciences & Earth Sciences (AREA)
- Soil Sciences (AREA)
- Environmental Sciences (AREA)
- Steering Control In Accordance With Driving Conditions (AREA)
Abstract
Priority Applications (3)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| JP2020553967A JP7423542B2 (ja) | 2018-10-30 | 2019-10-30 | ハンドル角制御装置 |
| KR1020217006478A KR20210082156A (ko) | 2018-10-30 | 2019-10-30 | 핸들각 제어 장치 |
| CN201980071100.4A CN112930298B (zh) | 2018-10-30 | 2019-10-30 | 方向盘角度控制装置 |
Applications Claiming Priority (2)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| JP2018-203760 | 2018-10-30 | ||
| JP2018203760 | 2018-10-30 |
Publications (1)
| Publication Number | Publication Date |
|---|---|
| WO2020090864A1 true WO2020090864A1 (fr) | 2020-05-07 |
Family
ID=70463787
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| PCT/JP2019/042505 Ceased WO2020090864A1 (fr) | 2018-10-30 | 2019-10-30 | Dispositif de commande d'angle de volant de direction |
Country Status (4)
| Country | Link |
|---|---|
| JP (1) | JP7423542B2 (fr) |
| KR (1) | KR20210082156A (fr) |
| CN (1) | CN112930298B (fr) |
| WO (1) | WO2020090864A1 (fr) |
Cited By (1)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| WO2025205460A1 (fr) * | 2024-03-27 | 2025-10-02 | 株式会社アイシン | Dispositif de commande de véhicule |
Citations (4)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JPH0986223A (ja) * | 1995-09-22 | 1997-03-31 | Mitsubishi Motors Corp | 自動運転装置 |
| JP2006103581A (ja) * | 2004-10-07 | 2006-04-20 | Honda Motor Co Ltd | 車両の操舵制御装置 |
| JP2017146819A (ja) * | 2016-02-18 | 2017-08-24 | 本田技研工業株式会社 | 車両制御システム、車両制御方法、および車両制御プログラム |
| JP2018103761A (ja) * | 2016-12-26 | 2018-07-05 | トヨタ自動車株式会社 | 自動運転車両 |
Family Cites Families (5)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| US20070118263A1 (en) | 2005-11-22 | 2007-05-24 | Nelson Frederick W | Direction determination utilizing vehicle yaw rate and change in steering position |
| EP2437586B9 (fr) | 2009-06-02 | 2019-02-13 | Topcon Precision Agriculture Pty Ltd | Système de guidage de véhicule |
| JP5965968B2 (ja) | 2014-11-19 | 2016-08-10 | 本田技研工業株式会社 | 電動パワーステアリング装置及び保舵支援制御装置 |
| JP6800028B2 (ja) * | 2017-01-20 | 2020-12-16 | 株式会社クボタ | 自動走行作業車 |
| CN207607530U (zh) * | 2017-10-31 | 2018-07-13 | 洛阳中科龙网创新科技有限公司 | 一种拖拉机转向的远程控制机构 |
-
2019
- 2019-10-30 WO PCT/JP2019/042505 patent/WO2020090864A1/fr not_active Ceased
- 2019-10-30 KR KR1020217006478A patent/KR20210082156A/ko not_active Ceased
- 2019-10-30 CN CN201980071100.4A patent/CN112930298B/zh not_active Expired - Fee Related
- 2019-10-30 JP JP2020553967A patent/JP7423542B2/ja active Active
Patent Citations (4)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JPH0986223A (ja) * | 1995-09-22 | 1997-03-31 | Mitsubishi Motors Corp | 自動運転装置 |
| JP2006103581A (ja) * | 2004-10-07 | 2006-04-20 | Honda Motor Co Ltd | 車両の操舵制御装置 |
| JP2017146819A (ja) * | 2016-02-18 | 2017-08-24 | 本田技研工業株式会社 | 車両制御システム、車両制御方法、および車両制御プログラム |
| JP2018103761A (ja) * | 2016-12-26 | 2018-07-05 | トヨタ自動車株式会社 | 自動運転車両 |
Cited By (1)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| WO2025205460A1 (fr) * | 2024-03-27 | 2025-10-02 | 株式会社アイシン | Dispositif de commande de véhicule |
Also Published As
| Publication number | Publication date |
|---|---|
| KR20210082156A (ko) | 2021-07-02 |
| CN112930298A (zh) | 2021-06-08 |
| CN112930298B (zh) | 2023-05-23 |
| JPWO2020090864A1 (ja) | 2021-09-16 |
| JP7423542B2 (ja) | 2024-01-29 |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| US10384609B2 (en) | Vehicle rear object proximity system using multiple cameras | |
| JP6860387B2 (ja) | 作業車 | |
| JP3721973B2 (ja) | 車両の操舵装置 | |
| EP1950120B1 (fr) | Volant de direction pour véhicules | |
| EP3900505B1 (fr) | Dispositif de commande pour véhicule de travail à déplacement automatique | |
| US20190391590A1 (en) | System and methods for detection and response to interference between trailer coupler and hitch ball | |
| JP5407514B2 (ja) | 無人搬送車の操舵駆動方法及び装置 | |
| US20190161086A1 (en) | Method and mechanism for assisted performance of a reverse-turning maneuver of a vehicle | |
| JP5338968B2 (ja) | 操舵制御装置 | |
| US11155298B2 (en) | Modified steering angle at completion of hitch assist operation | |
| JP6811655B2 (ja) | 作業車 | |
| US10946897B2 (en) | System and methods for steering control in assisted vehicle operation | |
| WO2020090862A1 (fr) | Dispositif de commande d'angle de volant de direction | |
| WO2020183988A1 (fr) | Engin de chantier | |
| US11679807B2 (en) | Driving assistance device for vehicle | |
| JP7268990B2 (ja) | 車両の自動操舵制御装置 | |
| JP7423542B2 (ja) | ハンドル角制御装置 | |
| US12612033B2 (en) | Hitch assist trailer, coupler and hitchball detection and tracking method | |
| JP2012232713A (ja) | 小型車両 | |
| JP6990079B2 (ja) | ステアリングシステム | |
| JPH08337181A (ja) | 車両の自動操舵装置 | |
| JP5267230B2 (ja) | 駐車支援装置および駐車支援方法 | |
| US11214105B2 (en) | Saturated steering detection and operation for guided vehicle operation | |
| JP2007253726A (ja) | 車両制御装置および車両制御方法 | |
| JP6997568B2 (ja) | ステアリングシステム |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| 121 | Ep: the epo has been informed by wipo that ep was designated in this application |
Ref document number: 19877718 Country of ref document: EP Kind code of ref document: A1 |
|
| ENP | Entry into the national phase |
Ref document number: 2020553967 Country of ref document: JP Kind code of ref document: A |
|
| NENP | Non-entry into the national phase |
Ref country code: DE |
|
| 122 | Ep: pct application non-entry in european phase |
Ref document number: 19877718 Country of ref document: EP Kind code of ref document: A1 |
|
| WWR | Wipo information: refused in national office |
Ref document number: 1020217006478 Country of ref document: KR |