WO2024257220A1 - Système de transport d'outil, procédé de commande d'un système de transport d'outil, et programme de commande d'un système de transport d'outil - Google Patents
Système de transport d'outil, procédé de commande d'un système de transport d'outil, et programme de commande d'un système de transport d'outil Download PDFInfo
- Publication number
- WO2024257220A1 WO2024257220A1 PCT/JP2023/021915 JP2023021915W WO2024257220A1 WO 2024257220 A1 WO2024257220 A1 WO 2024257220A1 JP 2023021915 W JP2023021915 W JP 2023021915W WO 2024257220 A1 WO2024257220 A1 WO 2024257220A1
- Authority
- WO
- WIPO (PCT)
- Prior art keywords
- tool
- tools
- transport
- group
- storage area
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Ceased
Links
Images







Classifications
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B23—MACHINE TOOLS; METAL-WORKING NOT OTHERWISE PROVIDED FOR
- B23Q—DETAILS, COMPONENTS, OR ACCESSORIES FOR MACHINE TOOLS, e.g. ARRANGEMENTS FOR COPYING OR CONTROLLING; MACHINE TOOLS IN GENERAL CHARACTERISED BY THE CONSTRUCTION OF PARTICULAR DETAILS OR COMPONENTS; COMBINATIONS OR ASSOCIATIONS OF METAL-WORKING MACHINES, NOT DIRECTED TO A PARTICULAR RESULT
- B23Q11/00—Accessories fitted to machine tools for keeping tools or parts of the machine in good working condition or for cooling work; Safety devices specially combined with or arranged in, or specially adapted for use in connection with, machine tools
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B23—MACHINE TOOLS; METAL-WORKING NOT OTHERWISE PROVIDED FOR
- B23Q—DETAILS, COMPONENTS, OR ACCESSORIES FOR MACHINE TOOLS, e.g. ARRANGEMENTS FOR COPYING OR CONTROLLING; MACHINE TOOLS IN GENERAL CHARACTERISED BY THE CONSTRUCTION OF PARTICULAR DETAILS OR COMPONENTS; COMBINATIONS OR ASSOCIATIONS OF METAL-WORKING MACHINES, NOT DIRECTED TO A PARTICULAR RESULT
- B23Q3/00—Devices holding, supporting, or positioning work or tools, of a kind normally removable from the machine
- B23Q3/155—Arrangements for automatic insertion or removal of tools, e.g. combined with manual handling
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B23—MACHINE TOOLS; METAL-WORKING NOT OTHERWISE PROVIDED FOR
- B23Q—DETAILS, COMPONENTS, OR ACCESSORIES FOR MACHINE TOOLS, e.g. ARRANGEMENTS FOR COPYING OR CONTROLLING; MACHINE TOOLS IN GENERAL CHARACTERISED BY THE CONSTRUCTION OF PARTICULAR DETAILS OR COMPONENTS; COMBINATIONS OR ASSOCIATIONS OF METAL-WORKING MACHINES, NOT DIRECTED TO A PARTICULAR RESULT
- B23Q41/00—Combinations or associations of metal-working machines not directed to a particular result according to classes B21, B23, or B24
Definitions
- the present disclosure relates to a tool transport system, a control method for a tool transport system, and a control program for a tool transport system.
- Patent Document 1 discloses a tool transport system that automatically transports tools used in machining to a machine tool.
- the tool transport system has a tool storage unit that can store multiple tools, and transports a specified tool to the machine tool.
- the tool transport system also removes tools that are holding unnecessary tools from the machine tool.
- Patent Document 1 controls the order in which tools are transported according to a predetermined transport schedule. If the efficiency of tool transport is poor, the tool transport time will be long. Therefore, there is a demand for technology to shorten the tool transport time of the tool transport system.
- a tool transport system includes a plurality of first machine tools for machining a workpiece using tools, a tool storage unit for storing the plurality of tools, a first transport device capable of transporting a specified tool from a group of tools including the tools inside the plurality of first machine tools and the tools inside the tool storage unit to a specified destination, and a control unit for controlling the tool transport system.
- the control unit executes a process of acquiring a transport schedule that specifies at least the destination for each of the plurality of tools to be transported, a process of referring to the transport schedule to determine, from among the plurality of tools to be transported, a group of tools whose destinations are close to each other as targets for collective transport, and a process of transporting the group of tools to be collective transported together to the first transport device.
- the determining process includes a process of identifying one tool among the multiple tools scheduled for transport that is scheduled to be transported closest to the present.
- the group of tools to be transported together includes the one tool and tools that have the same destination as the one tool.
- the tool storage section includes a first storage area and a second storage area.
- the first transport device is configured to transport a designated tool from a tool group including tools inside the plurality of first machine tools and tools in the first storage area to a designated destination.
- the tool transport system further includes a second machine tool and a second transport device capable of transporting a designated tool from a tool group including tools inside the second machine tool and tools in the second storage area to a designated destination.
- the determining process includes a process of determining a tool group stored in the first storage area, the tool group having a destination of the second machine tool, as the tool group to be transported collectively.
- the tool storage section further includes a third storage area used by both the first transport device and the second transport device.
- the third storage area is located between the first storage area and the second storage area.
- the transport process includes a process of controlling the first transport device so that the group of tools to be transported collectively are transported from the first storage area to the third storage area, and a process of controlling the second transport device so that after the group of tools to be transported collectively are transported from the first storage area to the third storage area, the group of tools to be transported collectively are transported directly or indirectly from the third storage area to the second machine tool.
- the tool transport system further includes a transport path along which the first transport device travels.
- a method for controlling a tool transport system includes a plurality of first machine tools for machining a workpiece using tools, a tool storage unit for storing the plurality of tools, and a first transport device capable of transporting a designated tool from a group of tools including the tools inside the plurality of first machine tools and the tools inside the tool storage unit to a designated destination.
- the control method includes a step of acquiring a transport schedule that specifies at least the destination for each of the plurality of tools to be transported, a step of referring to the transport schedule and determining, from among the plurality of tools to be transported, a group of tools whose destinations are close to each other as targets for collective transport, and a step of transporting the group of tools to be collective transported together to the first transport device.
- a control program for a tool transport system includes a plurality of first machine tools for machining a workpiece using tools, a tool storage unit for storing the plurality of tools, and a first transport device capable of transporting a designated tool from a group of tools including the tools inside the plurality of first machine tools and the tools inside the tool storage unit to a designated destination.
- the control program causes the tool transport system to execute the steps of: acquiring a transport schedule that specifies at least the destination for each of the plurality of tools to be transported; referring to the transport schedule, determining, from among the plurality of tools to be transported, a group of tools whose destinations are close to each other as targets for collective transport; and transporting the group of tools to be collective transported together to the first transport device.
- FIG. 1 is a diagram showing the appearance of a tool transport system.
- FIG. 2 is a diagram illustrating a configuration example of a drive mechanism of the tool transport system.
- 13A and 13B are diagrams illustrating a process of determining a tool to be transferred.
- FIG. 2 is a diagram illustrating an example of a functional configuration of a tool transport system.
- FIG. 13 is a diagram showing an example of processing settings.
- FIG. 13 illustrates an example of a work database.
- FIG. 13 is a diagram illustrating an example of a tool database.
- 13 is a diagram illustrating a schematic view of a group of tools to be transported together being transported together;
- FIG. 11 is a diagram illustrating a flow of a process of carrying a tool from a work station to a tool storage section.
- FIG. 1 is a diagram showing the appearance of a tool transport system.
- FIG. 2 is a diagram illustrating a configuration example of a drive mechanism of the tool transport system.
- FIG. 11 is a diagram showing storage information as an example. 10 is a diagram illustrating a flow of a process for carrying a tool from a tool storage unit to a machine tool.
- FIG. 1 is a diagram illustrating a flow of a process for carrying out a tool from a machine tool to a work station.
- FIG. FIG. 2 illustrates an example of a hardware configuration of a management apparatus. A diagram showing an example of the hardware configuration of a PLC (Programmable Logic Controller).
- FIG. 2 illustrates an example of a hardware configuration of an operation terminal.
- FIG. 2 is a diagram illustrating an example of a hardware configuration of a machine tool.
- FIG. 11 is a flowchart showing a batch transport process of tools.
- FIG. 11 is a flowchart showing a batch transport process of tools.
- FIG. 13 is a diagram illustrating a schematic configuration of a tool transport system according to a modified example.
- 13 is a diagram showing a state in which a group of tools to be transported together in a storage area are transported together from one storage area to another storage area;
- FIG. 13 is a diagram showing a state in which a group of tools to be transported together, which have been transported together to a storage area, are transported together to a machine tool;
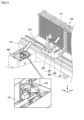
- Fig. 1 is a diagram showing the external appearance of the tool conveyance system 10.
- the tool transport system 10 includes a work station 200, a tool storage section 250, a transport device 300, and a machine tool 400.
- the work station 200 is a place where a worker works on tools. For example, the worker works at the work station 200 to set up tools or retrieve tools.
- the work station 200 includes an operation terminal 200A.
- the operation terminal 200A accepts various operations for the tool transport system 10.
- the tool storage section 250 can store multiple tools.
- the tool storage section 250 functions as a temporary storage area for tools.
- the transport device 300 transports tools from a specified source to a specified destination.
- Examples of the source of the tool include the work station 200, the tool storage unit 250, or the machine tool 400.
- Examples of the destination of the tool include the work station 200, the tool storage unit 250, or the machine tool 400.
- transport the transport mode in which the transport device 300 transports a tool from the work station 200 to the tool storage unit 250 or the machine tool 400, or the transport mode in which the transport device 300 transports a tool from the tool storage unit 250 to the machine tool 400, is also referred to as "transport.”
- transport The transport mode in which the transport device 300 transports tools from the tool storage unit 250 or the machine tool 400 to the work station 200, or the transport mode in which the transport device 300 transports tools from the machine tool 400 to the tool storage unit 250, is also referred to as "transport.”
- transport device as used in this specification is a concept that includes various devices that have the function of transporting tools.
- a 4- to 7-axis driven articulated robot will be described as an example of the transport device 300, but the transport device 300 is not limited to an articulated robot.
- the transport device 300 may be a 2- to 3-axis driven Cartesian robot (autoloader).
- the transport device 300 may be a self-propelled robot.
- the transport device 300 includes, for example, an arm robot 330, a rail 331, and a cart 332.
- the arm robot 330 is fixed onto the cart 332.
- the cart 332 is configured to be able to run on the rail 331 (transport path).
- the tool storage unit 250 and the machine tool 400 are arranged on either side of the rail 331 and parallel to the rail 331.
- the machine tool 400 is one of the destinations to which tools are transported by the transport device 300.
- six machine tools 400A to 400F are shown as the machine tools 400, but the number of machine tools 400 constituting the tool transport system 10 may be two or more.
- the machine tools 400 machine a workpiece using a specified tool according to a pre-designed machining program.
- the term "machine tool” as used in this specification is a concept that includes various devices that have the function of machining a workpiece.
- the machine tool 400 may be a horizontal machining center or a vertical machining center.
- the machine tool 400 may be a lathe, an additional processing machine, or any other cutting machine or grinding machine.
- the tool transport system 10 includes the work station 200, but the tool transport system 10 does not have to include the work station 200.
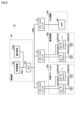
- FIG. 2 is a diagram showing an example of the configuration of the driving mechanisms in the tool conveyance system 10.
- the tool transport system 10 includes a control unit 50, remote I/O (Input/Output) units 71-73, a work station 200, a transport device 300, and a machine tool 400.
- control unit 50 remote I/O (Input/Output) units 71-73
- work station 200 work station 200
- transport device 300 transport device 300
- machine tool 400 machine tool 400
- control unit in this specification refers to a device that controls the tool transport system 10.
- the device configuration of the control unit 50 is arbitrary.
- the control unit 50 may be configured as a single control unit, or may be configured as multiple control units.
- the control unit 50 is configured from the management device 100, the PLC 150, and the above-mentioned operation terminal 200A.
- the control unit 50 may include a CNC (Computer Numerical Control) 401.
- the management device 100 is a main computer that manages the tool transport system 10.
- the management device 100 may be composed of one computer or multiple computers.
- the PLC 150 is configured to be able to communicate with various industrial devices for automating the machining process, and controls the industrial devices.
- the operation terminal 200A is a terminal for receiving various operations related to the loading and unloading of tools.
- the management device 100, PLC 150, and operation terminal 200A may be connected to a network NW1.
- the management device 100, PLC 150, and operation terminal 200A may be connected for communication via a wired or wireless connection.
- EtherNET registered trademark
- the management device 100 and operation terminal 200A send control commands to the PLC 150 via the network NW1.
- the control commands specify the tool to be transported, the destination of the tool, start/stop transport of the tool, etc.
- the remote I/O units 71-73 and the PLC 150 are connected to the network NW2.
- NW2 it is preferable to use a field network that performs periodic communication and guarantees the arrival time of data.
- field networks that perform such periodic communication include EtherCAT (registered trademark), EtherNet/IP (registered trademark), CC-Link (registered trademark), and CompoNet (registered trademark).
- the work station 200 includes one or more motor drivers 234 and one or more motors 235.
- motor drivers 234A, 234B and two motors 235A, 235B are shown.
- a remote I/O unit 71 is installed in or near the work station 200.
- the remote I/O unit 71 mediates data exchange between various drive units (e.g., motor driver 234) in the work station 200 and the PLC 150.
- the motor driver 234 receives control commands from the PLC 150 via the remote I/O unit 71 at regular intervals, and controls the drive of the motor 235 in accordance with the control commands.
- Motor 235A controls the driving of magazine M1 (see FIG. 9) in work station 200, which will be described later.
- Motor 235B controls the driving of ATC (Automatic Train Control) 238 (see FIG. 9) in work station 200, which will be described later.
- ATC Automatic Train Control
- Motor driver 234 may be, for example, a driver for a servo motor or a driver for a stepping motor.
- Motor 235 may be a servo motor or a stepping motor.
- the conveying device 300 includes one or more motor drivers 334 and one or more motors 335.
- motor drivers 334A and 334B and two motors 335A and 335B are shown.
- a remote I/O unit 72 is installed inside or near the conveying device 300.
- the remote I/O unit 72 mediates data exchange between various drive units (e.g., motor driver 334) inside the conveying device 300 and the PLC 150.
- the motor driver 334 receives control commands from the PLC 150 via the remote I/O unit 72 at regular intervals, and controls the drive of the motor 335 in accordance with the control commands.
- Motor 335A controls the driving of the above-mentioned cart 332 (see FIG. 1).
- Motor 335B controls the driving of arm robot 330 (see FIG. 1).
- Motors 335B are provided according to the number of joints of arm robot 330.
- Motor driver 334 may be, for example, a driver for a servo motor or a driver for a stepping motor.
- Motor 335 may be a servo motor or a stepping motor.
- a remote I/O unit 73 is installed in or near the machine tool 400.
- the machine tool 400 includes a CNC 401.
- the remote I/O unit 73 mediates data exchange between the PLC 150 and the CNC 401. For example, upon receiving a machining start command from the PLC 150, the CNC 401 controls various drive mechanisms within the machine tool 400 according to a machining program that has been designed in advance.
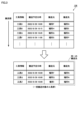
- Fig. 3 is a diagram showing a schematic diagram of a process of determining a tool to be transported.
- the tool transport system 10 transports a group of tools that are close to each other at the same time. This allows the tool transport system 10 to transport tools more efficiently and shorten the tool transport time.
- the tool transport system 10 acquires a tool transport schedule 126.
- the transport schedule 126 specifies at least the transport destination for each of the multiple tools scheduled for transport.
- the transport schedule 126 specifies, for each tool scheduled for transport, the tool identification information, the scheduled transport date and time of the tool, the storage location of the tool, and the transport destination of the tool.
- the tool identification information specified in the transport schedule 126 is information for uniquely identifying a tool.
- the identification information is assigned in advance to each tool.
- the identification information may be indicated by a tool number such as an ID (Identification) or may be indicated by the tool name.
- the planned transport date and time specified in the transport schedule 126 represents the start timing of the tool transport.
- the start timing is specified by a date and time, but the start timing may be specified by the remaining time from the present until the start of transport, or may be specified by other information capable of representing the start timing.
- the transfer origin defined in the transfer schedule 126 is information indicating the current storage location of the tool.
- the transfer origin is defined by information for uniquely identifying a location within the tool transfer system 10.
- the transfer origin indicates the storage position of the tool within the work station 200, the storage position of the tool within the tool storage section 250, the storage position of the tool within the transfer device 300, or the storage position of the tool within the machine tool 400. These storage positions are indicated, for example, by coordinate values.
- the transport destination specified in the transport schedule 126 is information indicating the destination of tool transport by the transport device 300.
- the transport destination is specified by information for uniquely identifying a location within the tool transport system 10.
- the transport destination indicates the tool storage position within the work station 200, the tool storage position within the tool storage section 250, the tool storage position within the transport device 300, or the tool storage position within the machine tool 400. These storage positions are indicated, for example, by coordinate values.
- the tool transport system 10 refers to the transport schedule 126 and determines, from among the multiple tools to be transported, a predetermined number of tools whose destinations are close to each other as the tools to be transported together.
- the tools to be transported together refer to the tools that are to be loaded onto the transport device 300 at the same time at least at one time.
- the tool transport system 10 refers to the transport schedule 126 to determine one reference tool to be transported.
- the reference tool is, for example, the tool scheduled to be transported next.
- "Tool D" is determined as the reference tool.
- the tool transport system 10 identifies a predetermined number of tools that are closest to the destination of the reference tool "tool D" from among the tools to be transported as specified in the transport schedule 126. In the example of FIG. 3, "tool G” and “tool Z” that have the same destination as “tool D” are identified. The tool transport system 10 then determines "tool D", “tool G”, and “tool Z” that have the same destination as “tool D” as the tools to be transported together, and transports the group of tools to be transported together to the transport device 300.
- the tool transport system 10 can transport tools efficiently by transporting a group of tools whose destinations are close to each other at the same time, thereby shortening the tool transport time.
- the tool transport system 10 determines the group of tools to be transported together based on the destination of the tools, but the group of tools to be transported together may be determined by taking into consideration not only the destination of the tools but also the source of the tools. As an example, the tool transport system 10 determines, as the group of tools to be transported together, tool groups whose sources are close to each other and whose destinations are close to each other. This allows the tool transport system 10 to transport tool groups with similar transport routes together, thereby further shortening the transport time.
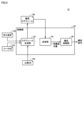
- Fig. 4 is a diagram showing an example of the functional configuration of the tool transport system 10.
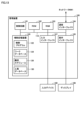
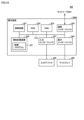
- the tool transport system 10 includes a control unit 50.
- the control unit 50 includes, as its functional components, a schedule generation unit 52, a determination unit 54, and a transport control unit 56. Below, these functional components will be described in order.
- each functional configuration may be implemented in any device within the tool transport system 10. Some or all of the functional configurations shown in FIG. 4 may be implemented in the above-mentioned management device 100 (see FIG. 2), the above-mentioned PLC 150 (see FIG. 2), the above-mentioned operation terminal 200A (see FIG. 1), or the above-mentioned CNC 401 (see FIG. 2).
- the schedule generation unit 52 generates the above-mentioned transport schedule 126 (see FIG. 3) based on the processing settings 123 shown in FIG. 5, the work database 124 shown in FIG. 6, and the tool database 130 shown in FIG. 7.
- FIG. 5 is a diagram showing an example of processing settings 123.
- the worker registers the workpieces to be processed in advance by registering the processing settings 123.
- the processing settings 123 are registered by the worker, for example, in the above-mentioned management device 100 or the above-mentioned operation terminal 200A.
- the contents registered by the worker include, for example, identification information of the workpieces to be processed, the number of workpieces to be processed, and the processing order of the workpieces.
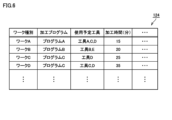
- FIG. 6 is a diagram showing an example of the workpiece database 124.
- the workpiece database 124 associates, for each workpiece's identification information, a machining program for machining the workpiece, a tool to be used when machining the workpiece, a machining time required to machine the workpiece, and other information related to the machining of the workpiece.
- the machining program defined in the work database 124 is registered by an operator, for example, in the above-mentioned management device 100, the above-mentioned operation terminal 200A, or the above-mentioned machine tool 400.
- the method of generating the machining program is arbitrary.
- some machine tools 400 have a function of automatically generating a machining program by having the operator answer questions in an interactive format.
- the machining program is generated, for example, by this function.
- the machining program may be designed by the operator writing program code.
- the tools to be used which are specified in the work database 124, are set in advance by the user, for example.
- the tools to be used may be identified from the machining program. More specifically, the machining program specifies a command code for calling the tools to be used.
- the command code is, for example, a T-code for specifying the tool to be attached to the spindle.
- the schedule generation unit 52 searches for the T-code from each machining program to identify the identification information of the tool to be used in machining each workpiece.
- the processing time specified in the work database 124 is, for example, input in advance by an operator. Alternatively, the processing time may be calculated from the past processing results of each work.
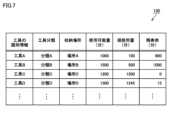
- FIG. 7 is a diagram showing an example of the tool database 130.
- the tool database 130 associates, as information for each tool, the identification information of the tool, the tool classification assigned to the tool, the storage location of the tool, the available amount of the tool, the current amount of use of the tool, and the remaining life of the tool.
- the "amount” here is a concept that includes time, distance, and number of times.
- the tool identification information defined in the tool database 130 is information for uniquely identifying a tool.
- the identification information is assigned in advance to each tool.
- the identification information may be indicated by a tool number such as an ID, or may be indicated by the tool name.
- the tool classification defined in the tool database 130 is information indicating the type of tool, and is assigned in advance to each tool.
- the tool classification is set in advance by the worker.
- the setting of the tool classification may be accepted, for example, by the management device 100 or by the work station 200.
- the type may be indicated by a group number such as an ID, or may be indicated by a group name.
- the storage locations defined in the tool database 130 are information indicating the location of the tool.
- the storage locations are updated each time a tool is transported. Examples of storage locations include the work station 200, the tool storage unit 250, the transport device 300, and the machine tool 400.
- the usable amount specified in the tool database 130 indicates the maximum usable amount of a tool from when it is new until the end of its life.
- the usable amount of each tool is determined in advance by the tool manufacturer or the like, and is registered in advance in the tool database 130.
- the current usage amount specified in the tool database 130 indicates the amount of tool usage from when the tool was new to the present.
- the current usage amount is periodically received from the machine tool 400.
- the remaining lifespan specified in the tool database 130 indicates the remaining usage of the tool from the present until the end of its lifespan. Typically, the remaining lifespan corresponds to the result of subtracting the current usage of the tool from the maximum usable amount of the tool.
- the current usage and remaining life specified in the tool database 130 are updated successively.
- the current usage and remaining life are monitored by various methods.
- the machining program of the machine tool 400 is specified in G-code, and includes a tool change command for specifying the tool to be attached to the spindle, and a drive command for rotating/feeding the spindle and tool.
- the tool transport system 10 specifies the type of tool to be used for machining the workpiece based on the tool change command specified in the machining program.
- the tool transport system 10 starts counting down the remaining life of the tool based on the execution of the drive command specified in the machining program.
- the tool transport system 10 stops counting down the remaining life of the tool based on the execution of the stop command or the last command specified in the machining program.
- the remaining life is transmitted to the management device 100.
- the management device 10 updates the remaining life of each tool in the tool database 130.
- the schedule generation unit 52 refers to the workpiece database 124 to identify the tools required for machining each workpiece defined in the machining settings 123. Next, the schedule generation unit 52 refers to the tool database 130 to determine, among the identified tools, those that are not present in the destination machine tool 400 as tools to be transported. Thereafter, the schedule generation unit 52 refers to the tool database 130 to identify the tool information of each tool to be transported, the planned transport date and time of the tool, the transport source (storage location) of the tool, and the transport destination of the tool, and writes this identified information into the transport schedule 126. In this way, the transport schedule 126 is generated.
- the determination unit 54 refers to the above-mentioned transport schedule 126 and determines, from among the tools scheduled for transport, a predetermined number of tools whose destinations are close to each other as the tools to be transported collectively.
- the timing at which the tools to be transported collectively are determined is arbitrary. As one example, the timing may be the timing at which the transport time of any of the tools scheduled for transport arrives, or may be a predetermined time before the transport time.
- the determination unit 54 identifies, as a reference tool, one tool that is scheduled to be transported and that is specified in the transport schedule 126 and that has the closest planned transport timing to the present.
- the determination unit 54 identifies a tool that has the same transport destination as the reference tool, and determines the identified tool and the reference tool as a group of tools to be transported together. This allows the determination unit 54 to improve the efficiency of tool transport while preferentially transporting the most recently used tool.
- the determination unit 54 calculates the distance between the destination of the reference tool and the destinations of each of the other tools. The distance is calculated, for example, using position information (for example, coordinate values) of the destinations. Next, the determination unit 54 identifies a predetermined number of tools whose calculated distances are shorter. Thereafter, the determination unit 54 determines the identified tools and the reference tool as a group of tools to be transported together.
- the determination unit 54 calculates the similarity between the transport route of the reference tool and the transport route of each of the other tools. More specifically, the determination unit 54 calculates a first distance between the transport source of the reference tool and the transport source of each of the other tools. Next, the determination unit 54 calculates a second distance between the transport destination of the reference tool and the transport destination of each of the other tools. Next, the determination unit 54 adds up the first distance and the second distance for each of the other tools, and calculates the calculation result as the similarity. Next, the determination unit 54 identifies a predetermined number of tools having a smaller calculated similarity. Thereafter, the determination unit 54 determines the reference tool and the identified tools as a group of tools to be transported together.
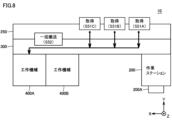
- Fig. 8 is a diagram showing a schematic view of a group of tools to be transferred collectively being transferred collectively.
- the transport control unit 56 controls the transport device 300 so that the group of tools to be transported together, as determined by the determination unit 54, are transported together.
- the transport device 300 acquires the group of tools to be transported together from each location in the tool storage section 250.
- the order in which the tools are acquired at this time is arbitrary.
- the transport device 300 acquires each tool in order of furthest from the destination. This allows the transport device 300 to efficiently acquire each tool to be transported together.
- step S52 the transport device 300 transports the acquired group of tools to be transported together to the specified destination.
- the group of tools to be transported together is transported from the tool storage unit 250 to the machine tool 400A.
- Figure 9 is a diagram showing a schematic flow of the process of carrying a tool from the work station 200 to the tool storage unit 250.
- step S1 the worker sets the tool holder H1 to be loaded into the magazine M1 in the work station 200.
- the tool to be loaded is attached to the tool holder H1.
- the number of tool holders that can be stored in the work station 200 is less than the number of tool holders that can be stored in the tool storage section 250.
- a barcode or QR code (registered trademark) reader (not shown) is provided near the position where the worker sets the tool holder H1 in the magazine M1.
- the reader reads the barcode or QR code attached to the tool holder H1. This allows the identifier of the tool holder H1 to be loaded to be read.
- the worker has finished setting the tool holder H1, he or she performs a completion operation on the operation terminal 200A.
- step S2 the control unit 50 controls the motor 235A (see FIG. 2) to drive the magazine M1 in the work station 200.
- the control unit 50 moves the tool holder H1 to be loaded to a predetermined tool exchange position.
- the ATC 238 is provided near the tool exchange position. The ATC 238 removes the tool holder H1 at the tool exchange position from the magazine M1 and rotates it half a turn.
- step S3 the arm robot 330 removes the tool holder H1 from the ATC 238 and places the tool holder H1 in the temporary storage area 336 on the cart 332. If there are other tool holders to be brought in, steps S1 to S3 are repeated as long as the number of tool holders does not exceed the maximum number that can be stored in the temporary storage area 336.
- step S4 the control unit 50 controls the motor 335A (see FIG. 2) to drive the cart 332.
- the control unit 50 moves the cart 332 to the instructed tool loading position.
- the tool loading position is determined, for example, based on the storage information 175 shown in FIG. 10.
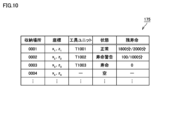
- FIG. 10 is a diagram showing an example of storage information 175.
- Storage information 175 is information that specifies the tool storage status in each tool storage location within tool transport system 10.
- the storage location defined in the storage information 175 may be indicated by a number such as an ID, or may be indicated by the name of the storage location.
- the coordinate values of the storage location defined in the storage information 175 may be specified in two dimensions or in three dimensions. In the example of FIG. 10, the coordinate values are indicated by a coordinate value "x" in a direction parallel to the rail 331 and a coordinate value "z" in a vertical direction.
- the identification information of the tool defined in the storage information 175 may be indicated by a tool number such as an ID, or may be indicated by the tool name.
- the storage status defined in the storage information 175 indicates, for example, whether the storage location is empty or not, or whether the tool stored in the storage location is normal or not.
- the remaining life of the tool defined in the storage information 175 may be indicated by the current total usage time relative to the maximum usable time of the tool, or may be indicated by the current total number of usage times relative to the maximum usable times of the tool.
- the control unit 50 determines the storage destination of the tool holder H1 by referring to the empty storage locations specified in the storage information 175. If there are multiple empty storage locations, the control unit 50 may determine one storage location randomly selected from the multiple empty storage locations as the storage destination, or may determine one of the multiple empty storage locations that is closest to the conveying device 300 as the storage destination.
- step S5 the arm robot 330 removes the tool holder H1 to be carried in from the temporary storage area 336 and stores the tool holder H1 in the determined storage location.
- the control unit 50 updates the storage information 175 by associating the identifier of the tool holder H1 with the corresponding storage location.
- control unit 50 repeats steps S4 and S5 until there are no more tool holders remaining in the temporary storage area 336.
- Fig. 11 is a diagram showing a schematic flow of the tool carrying-in process from the tool storage unit 250 to the machine tool 400.
- the control unit 50 identifies the tool to be brought in and the machine tool 400 to which it is to be brought in, according to the above-mentioned transport schedule 126. As a result, it is assumed that tool holder H2 is identified as the tool to be brought in. In this case, the control unit 50 identifies the storage location of tool holder H2 from the above-mentioned storage information 175 (see FIG. 10). Thereafter, the control unit 50 drives the cart 332 by controlling the motor 335A (see FIG. 2), and moves the cart 332 to the front of the storage location of tool holder H2.
- step S11 the arm robot 330 removes the tool holder H2 to be transported from the tool storage section 250 and places the tool holder H2 in the temporary storage area 336 on the cart 332.
- step S12 the control unit 50 controls the motor 335A to drive the carriage 332 to the position of the destination machine tool 400.
- step S13 the arm robot 330 delivers the tool holder H2 to the ATC 438 provided in the destination machine tool 400.
- the ATC 438 then sets the tool holder H2 in a magazine inside the machine tool 400.
- Fig. 12 is a diagram showing a schematic flow of the process of carrying out the tool from the machine tool 400 to the work station 200.
- the control unit 50 receives a tool holder recovery instruction. Based on this, the control unit 50 identifies a tool holder to be recovered from among the tool holders stored in the machine tool 400. As a result, it is assumed that the tool holder H3 is identified as the tool holder to be recovered.
- the control unit 50 identifies the storage destination of the tool holder H3 by referring to the above-mentioned storage information 175 (see FIG. 10). Thereafter, the control unit 50 drives the cart 332 by controlling the above-mentioned motor 335A (see FIG. 2) and moves the cart 332 in front of the machine tool 400 storing the tool holder H3.
- the arm robot 330 takes out the tool holder H3 from the machine tool 400 and places the tool holder H3 in the temporary storage area 336 on the cart 332.
- the control unit 50 also deletes the identifier of the tool holder H3 from the storage information 175 and rewrites the storage source of the tool holder H3 to an empty state.
- step S21 the control unit 50 drives the carriage 332 by controlling the above-mentioned motor 335A, and moves the carriage 332 from in front of the machine tool 400 to in front of the work station 200.
- step S22 the arm robot 330 removes the tool holder H3 to be removed from the temporary storage area 336, and attaches the tool holder H3 to the ATC 238 (see FIG. 9) provided in the work station 200.
- the ATC 238 then attaches the tool holder H3 to the magazine M1 of the work station 200.
- step S23 the control unit 50 controls the motor 235A to drive the magazine M1 and move the tool holder H3 to be removed to the front of the exit. After that, the worker removes the tool holder H3 to be removed from the exit.
- Fig. 13 is a diagram showing an example of the hardware configuration of the management device 100.
- the management device 100 includes a control circuit 101, a ROM (Read Only Memory) 102, a RAM (Random Access Memory) 103, a communication interface 104, a display interface 105, an input interface 107, and an auxiliary storage device 120. These components are connected to a bus 110.
- the control circuit 101 is composed of at least one integrated circuit.
- the integrated circuit may be composed of, for example, at least one CPU (Central Processing Unit), at least one GPU (Graphics Processing Unit), at least one ASIC (Application Specific Integrated Circuit), at least one FPGA (Field Programmable Gate Array), or a combination thereof.
- CPU Central Processing Unit
- GPU Graphics Processing Unit
- ASIC Application Specific Integrated Circuit
- FPGA Field Programmable Gate Array
- the control circuit 101 controls the operation of the management device 100 by executing various programs such as a control program 122 and an operating system. Based on receiving an execution command for the control program 122, the control circuit 101 reads the control program 122 from the auxiliary storage device 120 or ROM 102 to the RAM 103.
- the RAM 103 functions as a working memory and temporarily stores various data required for the execution of the control program 122.
- a LAN Local Area Network
- an antenna etc. are connected to the communication interface 104.
- the management device 100 is connected to the network NW1 via the communication interface 104. This allows the management device 100 to exchange data with external devices connected to the network NW1.
- the external devices include, for example, a PLC 150 and a server (not shown).
- the display interface 105 is connected to the display 106.
- the display interface 105 sends an image signal for displaying an image to the display 106 in accordance with instructions from the control circuit 101 or the like.
- the display 106 displays, for example, an operation screen for receiving interrupt instructions for processing.
- the display 106 is, for example, a liquid crystal display, an organic EL (Electro Luminescence) display, or other display device.
- the display 106 may be configured integrally with the management device 100, or may be configured separately from the management device 100.
- An input device 108 is connected to the input interface 107.
- the input device 108 is, for example, a mouse, a keyboard, a touch panel, or any other device capable of accepting user operations.
- the input device 108 may be configured integrally with the management device 100, or may be configured separately from the management device 100.
- the auxiliary storage device 120 is a storage medium such as a hard disk or flash memory.
- the auxiliary storage device 120 stores the control program 122, the above-mentioned work database 124, the above-mentioned transport schedule 126, and the above-mentioned tool database 130.
- the storage location of these is not limited to the auxiliary storage device 120, and may be stored in the memory area of the control circuit 101 (for example, cache memory), the ROM 102, the RAM 103, or other devices (for example, a server, the PLC 150, or the operation terminal 200A), etc.
- the control program 122 is a program for realizing some or all of the functional configuration shown in FIG. 4 above.
- the control program 122 may be provided not as a stand-alone program, but incorporated as part of any program. Even if the program does not include some of these modules, it does not deviate from the spirit of the control program 122 according to this embodiment.
- some or all of the functions provided by the control program 122 may be realized by dedicated hardware.
- the management device 100 may be configured in the form of a so-called cloud service in which at least one server executes part of the processing of the control program 122.
- FIG. 14 is a diagram showing an example of a hardware configuration of the PLC 150.
- PLC 150 includes a control circuit 151, a ROM 152, a RAM 153, communication interfaces 154 and 155, and an auxiliary storage device 170. These components are connected to a bus 160.
- the control circuit 151 is composed of at least one integrated circuit.
- the integrated circuit is composed of, for example, at least one CPU, at least one MPU (Micro Processing Unit), at least one ASIC, at least one FPGA, or a combination thereof.
- the control circuit 151 controls the operation of the conveying device 300, the machine tool 400, etc. by executing various programs such as the control program 172. Based on receiving an execution command for the control program 172, the control circuit 151 reads the control program 172 from the auxiliary storage device 170 to the ROM 152.
- the RAM 153 functions as a working memory, and temporarily stores various data required for the execution of the control program 172.
- a LAN, an antenna, etc. are connected to the communication interface 154.
- the PLC 150 is connected to the network NW1 via the communication interface 154. This allows the PLC 150 to exchange data with external devices connected to the network NW1.
- external devices include, for example, the management device 100 and a server (not shown).
- the communication interface 155 is an interface for connecting to the network NW2, which is a field network.
- the PLC 150 exchanges data with external devices connected to the network NW2 via the communication interface 155.
- external devices include, for example, the above-mentioned remote I/O units 71 to 73.
- the auxiliary storage device 170 is a storage medium such as a hard disk or flash memory.
- the auxiliary storage device 170 stores the control program 172 and the above-mentioned storage information 175.
- the storage location of these is not limited to the auxiliary storage device 170, and may be stored in the storage area of the control circuit 151 (e.g., a cache area), the ROM 152, the RAM 153, an external device (e.g., a server), etc.
- the control program 172 is a program for realizing all or part of the functional configuration shown in FIG. 4 above.
- the control program 172 may be provided not as a standalone program, but incorporated as part of an arbitrary program. In this case, the control processing according to this embodiment is realized in cooperation with the arbitrary program. Even if the program does not include some of these modules, it does not deviate from the spirit of the control program 172 according to this embodiment.
- all or part of the functions provided by the control program 172 may be realized by dedicated hardware.
- the PLC 150 may be configured in the form of a so-called cloud service in which at least one server executes part of the processing of the control program 172.
- FIG. 15 is a diagram showing an example of the hardware configuration of the operation terminal 200A.
- the operation terminal 200A includes a control circuit 201, a ROM 202, a RAM 203, a communication interface 204, a display interface 205, an input interface 207, and an auxiliary storage device 220. These components are connected to a bus 210.
- the control circuit 201 is composed of at least one integrated circuit.
- the integrated circuit may be composed of, for example, at least one CPU, at least one GPU, at least one ASIC, at least one FPGA, or a combination thereof.
- the control circuit 201 controls the operation of the operation terminal 200A by executing various programs such as the control program 222 and the operating system. Based on receiving an execution command for the control program 222, the control circuit 201 reads the control program 222 from the auxiliary storage device 220 or the ROM 202 to the RAM 203.
- the RAM 203 functions as a working memory and temporarily stores various data required for the execution of the control program 222.
- a LAN, an antenna, etc. are connected to the communication interface 204.
- the operation terminal 200A is connected to the network NW1 via the communication interface 204. This allows the operation terminal 200A to exchange data with external devices connected to the network NW1.
- the external devices include, for example, the PLC 150 and a server (not shown).
- the display interface 205 is connected to the display 206.
- the display interface 205 sends image signals for displaying images to the display 206 in accordance with commands from the control circuit 201 and the like.
- the display 206 displays, for example, an operation screen for receiving instructions to carry in tools, a tool selection screen for specifying the tool to be transported, or a machine tool selection screen for specifying the machine tool 400 to be transported.
- the display 206 is, for example, a liquid crystal display, an organic EL display, or other display device.
- the display 206 may be configured integrally with the operation terminal 200A, or may be configured separately from the operation terminal 200A.
- An input device 208 is connected to the input interface 207.
- the input device 208 is, for example, a mouse, a keyboard, a touch panel, or any other device capable of accepting user operations.
- the input device 208 may be configured integrally with the operation terminal 200A, or may be configured separately from the operation terminal 200A.
- the auxiliary storage device 220 is a storage medium such as a hard disk or flash memory.
- the auxiliary storage device 220 stores the control program 222 of the operation terminal 200A and the like.
- the storage location of the control program 222 is not limited to the auxiliary storage device 220, and may be stored in a memory area of the control circuit 201 (such as a cache memory), the ROM 202, the RAM 203, an external device (such as a server), etc.
- FIG. 16 is a diagram showing an example of a hardware configuration of the machine tool 400.
- the machine tool 400 includes a CNC 401, a ROM 402, a RAM 403, a communication interface 404, motor drivers 411A-411D, motors 412A-412D, encoders 413A-413D, ball screws 414A and 414B, and a spindle 415 for attaching a tool. These devices are connected via a bus (not shown).
- CNC401 is composed of at least one integrated circuit.
- the integrated circuit is composed of, for example, at least one CPU, at least one MPU, at least one ASIC, at least one FPGA, or a combination thereof.
- the CNC 401 controls the operation of the machine tool 400 by executing various programs such as a machining program 422. Upon receiving an execution command for the machining program 422, the CNC 401 reads the machining program 422 from the auxiliary storage device 420 to the ROM 402.
- the RAM 403 functions as a working memory and temporarily stores various data required for the execution of the machining program 422.
- the communication interface 404 is an interface for realizing communication with the PLC 151 via the remote I/O unit 73.
- the CNC 401 exchanges data with the PLC 151 via the communication interface 404.
- the CNC 401 controls the motor drivers 411A to 411D according to the machining program 422.
- Each of the motor drivers 411A to 411D may be, for example, a driver for a servo motor or a driver for a stepping motor.
- the CNC 401 sequentially outputs a control signal including a target rotation speed (or target position) to the motor driver 411A.
- the motor driver 411A calculates the actual rotation speed (or actual position) of the motor 412A from the feedback signal of the encoder 413A, and outputs a current to the motor 412A so that the difference between the actual rotation speed and the target rotation speed becomes small.
- the motor driver 411A sequentially receives feedback of the rotation speed of the motor 412A and brings the rotation speed of the motor 412A closer to the target rotation speed.
- the motor driver 411A moves the workpiece setting table connected to the ball screw 414A to any position in the X-axis direction.
- the CNC 401 sequentially outputs a control signal including a target rotation speed (or target position) to the motor driver 411B.
- the motor driver 411B calculates the actual rotation speed (or actual position) of the motor 412B from the feedback signal of the encoder 413B, and outputs a current to the motor 412B so that the difference between the actual rotation speed and the target rotation speed becomes small.
- the motor driver 411B sequentially receives feedback of the rotation speed of the motor 412B and brings the rotation speed of the motor 412B closer to the target rotation speed.
- the motor driver 411B moves the workpiece setting table connected to the ball screw 414B to an arbitrary position in the Y-axis direction.
- the CNC 401 sequentially outputs a control signal including a target rotation speed (or target position) to the motor driver 411C.
- the motor driver 411C calculates the actual rotation speed (or actual position) of the motor 412C from the feedback signal of the encoder 413C, and outputs a current to the motor 412C so that the difference between the actual rotation speed and the target rotation speed becomes small.
- the motor driver 411C sequentially receives feedback of the rotation speed of the motor 412C and brings the rotation speed of the motor 412C closer to the target rotation speed. In this way, the motor driver 411C moves the spindle 415 to an arbitrary position in the Z-axis direction.
- the CNC 401 sequentially outputs a control signal including a target rotation speed (or target position) to the motor driver 411D.
- the motor driver 411D calculates the actual rotation speed (or actual position) of the motor 412D from the feedback signal of the encoder 413D, and outputs a current to the motor 412D so as to reduce the difference between the actual rotation speed and the target rotation speed.
- the motor driver 411D sequentially receives feedback of the rotation speed of the motor 412D and brings the rotation speed of the motor 412D closer to the target rotation speed. In this way, the motor driver 411D controls the rotation speed of the spindle 415.
- the auxiliary storage device 420 is a storage medium such as a hard disk or a flash memory.
- the auxiliary storage device 420 stores the machining program 422 and the like.
- the storage location of the machining program 422 is not limited to the auxiliary storage device 420, and may be stored in the memory area of the CNC 401 (e.g., a cache area), the ROM 402, the RAM 403, an external device (e.g., a server), etc.
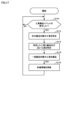
- Fig. 17 is a diagram showing a flowchart relating to the batch transfer processing of tools.
- the process shown in FIG. 17 is realized by the control unit 50 of the tool transport system 10 executing a control program. In other aspects, some or all of the process may be performed by circuit elements or other hardware.
- step S110 the control unit 50 determines whether a tool transport event has occurred.
- Tool transport events occur at various times. As one example, a tool transport event occurs based on the arrival of a scheduled transport date and time specified in the tool transport schedule 126 (see FIG. 3).
- control unit 50 determines that a tool transport event has occurred (YES in step S110), it switches control to step S112. If not (NO in step S110), the control unit 50 returns control to step S110.
- control unit 50 functions as the determination unit 54 described above (see FIG. 4) and refers to the transport schedule 126 to identify the next tool scheduled to be transported as the reference tool.
- step S114 the control unit 50 functions as the determination unit 54 described above, and refers to the transport schedule 126 to identify one or more tools whose destinations are close to the reference tool identified in step S112.
- step S116 the control unit 50 functions as the above-mentioned transport control unit 56 (see FIG. 4) and causes the transport device 300 to transport the tool identified in step S112 and one or more tools identified in step S114 as a group of tools to be transported together.
- the number of tools transported in a batch is equal to or less than the maximum number that can be stored in the temporary storage area 336 (see FIG. 9) of the transport device 300.
- the maximum number of tools transported in a batch is the maximum number that can be stored in the temporary storage area 336 minus 1.
- the transport device 300 leaves one storage location on the temporary storage area 336 open as a buffer, allowing tools to be exchanged via the buffer.
- step S118 the control unit 50 updates various information that specifies the storage locations of the tools based on the fact that the group of tools to be transported together have been transported to each destination.
- Examples of the various information that is updated include the above-mentioned transport schedule 126, the above-mentioned tool database 130, and the above-mentioned storage information 175.
- the control unit 50 returns control to step S110 based on the completion of the processing of step S118.
- Fig. 18 is a diagram showing a schematic device configuration of a tool transport system 10A according to a modified example.
- the above-mentioned tool transport system 10 is composed of one transport device 300.
- the tool transport system 10A according to this modified example is composed of multiple transport devices 300.
- the tool transport system 10A is composed of two transport devices 300R, 300L.
- transport devices 300R and 300L are shown mounted on the same rail, but the transport devices 300R and 300L may be mounted on separate rails.
- the tool transport system 10A includes a work station 200, a tool storage unit 250, transport devices 300R and 300L, and machine tools 400A to 400C.
- the tool storage section 250 is separated into storage areas AR1 to AR3.
- Each of the storage areas AR1 to AR3 may be a continuous area or may be physically separated areas.
- Storage area AR1 (first storage area) is a tool storage area that is used by conveying device 300R and is not used by conveying device 300L.
- Storage area AR2 (second storage area) is a tool storage area that is used by conveying device 300L and is not used by conveying device 300R.
- Storage area AR3 (third storage area) is a tool storage area that is used by both conveying device 300R and conveying device 300L.
- the transport device 300R is responsible for transporting tools to machine tools 400A and 400B among the machine tools 400A to 400C.
- machine tool 400R first machine tool
- the transport device 300R is configured to transport a specified tool from a group of tools including the tools inside the machine tool 400R and the tools in the storage areas AR1 and AR3 to a specified destination. Destinations for tools transported by the transport device 300R include, for example, the work station 200, the storage area AR1, the storage area AR3, or the machine tool 400R.
- the transport device 300L is responsible for transporting tools to machine tool 400C among the machine tools 400A to 400C.
- machine tool 400L second machine tool
- the transport device 300L is configured to transport a specified tool from a group of tools including the tools inside the machine tool 400L and the tools in the storage areas AR2 and AR3 to a specified destination.
- Examples of destinations for tools transported by the transport device 300L include the storage area AR2, the storage area AR3, or the machine tool 400L.
- control unit 50 of the tool transport system 10A transports a tool in the area covered by the transport device 300R to outside the area covered by the transport device 300R, it also transports other tools whose destinations are outside the area covered by the transport device 300R.
- Figure 19 is a diagram showing how a group of tools to be transported collectively in storage area AR1 is transported collectively from storage area AR1 to storage area AR3.
- Figure 20 is a diagram showing how the group of tools to be transported collectively, which have been transported collectively to storage area AR3, are transported collectively to machine tool 400L.
- control unit 50 determines that the reference tool and one or more tools stored in storage area AR1 that have the same destination as the reference tool as a group of tools to be transported together.
- step S61 the control unit 50 controls the conveying device 300R so that the group of tools to be conveyed collectively is conveyed from the storage area AR1 to the storage area AR3.
- step S62 the control unit 50 controls the conveying device 300L so that the group of tools to be conveyed collectively is conveyed directly or indirectly from the storage area AR3 to the machine tool 400L.
- the group of tools to be transported together may be finally transported to the machine tool 400L. That is, the group of tools to be transported together may be transported directly from the storage area AR3 to the machine tool 400L, or may be transported from the storage area AR3 to the storage area AR2 and then transported from the storage area AR2 to the machine tool 400L.
- control unit 50 determines that the reference tool and one or more tools stored in storage area AR2 that have the same destination as the reference tool as a group of tools to be transported together.
- control unit 50 controls the conveying device 300L so that the group of tools to be conveyed collectively is conveyed from the storage area AR2 to the shared storage area AR3.
- the control unit 50 then controls the conveying device 300R so that the group of tools to be conveyed collectively is conveyed directly or indirectly from the storage area AR3 to the machine tool 400R.
- the group of tools to be transported together may ultimately be transported to the machine tool 400R. That is, the group of tools to be transported together may be transported directly from the storage area AR3 to the machine tool 400R, or may be transported from the storage area AR3 to the storage area AR1 and then transported from the storage area AR1 to the machine tool 400R.
- 10 Tool transport system 10A Tool transport system, 50 Control unit, 52 Schedule generation unit, 54 Decision unit, 56 Transport control unit, 71 Remote I/O unit, 72 Remote I/O unit, 73 Remote I/O unit, 100 Management device, 101 Control circuit, 102 ROM, 103 RAM, 104 Communication interface, 105 Display interface, 106 Display, 107 Input interface, 108 Input device, 110 Bus, 120 Auxiliary storage device, 122 Control program, 123 Machining settings, 124 Work database, 126 Transport schedule, 130 Machining Tool database, 151 control circuit, 152 ROM, 153 RAM, 154 communication interface, 155 communication interface, 160 bus, 170 auxiliary storage device, 172 control program, 175 storage information, 200 work station, 200A operation terminal, 201 control circuit, 202 ROM, 203 RAM, 204 communication interface, 205 display interface, 206 display, 207 input interface, 208 input device, 210 bus, 220 auxiliary storage device, 222 control program, 234 motor driver, 234A motor driver, 234
Landscapes
- Engineering & Computer Science (AREA)
- Mechanical Engineering (AREA)
- General Factory Administration (AREA)
Abstract
Un système de transport d'outils (10) comprend : une pluralité de machines-outils (400) destinés à traiter une pièce à l'aide d'outils ; une unité de stockage d'outils (250) destinée à stocker une pluralité d'outils ; un dispositif de transport (300) capable de transporter des outils désignés dans un groupe d'outils comprenant les outils à l'intérieur de la pluralité de machines-outils (400) et les outils à l'intérieur de l'unité de stockage d'outils (250) vers une destination de transport désignée ; et une unité de commande (50) destinée à commander le système de transport d'outils (10). L'unité de commande (50) exécute : un processus destiné à acquérir un calendrier de transport qui spécifie au moins une destination de transport pour chacun d'une pluralité d'outils programmés pour le transport ; un processus pour se référer au calendrier de transport et déterminer, en tant que cibles pour un transport collectif, un groupe d'outils ayant des destinations de transport qui sont proches les unes des autres parmi la pluralité d'outils programmés pour le transport ; et un processus destiné à transporter collectivement le groupe d'outils qui sont des cibles pour un transport collectif vers le dispositif de transport (300).
Priority Applications (2)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| PCT/JP2023/021915 WO2024257220A1 (fr) | 2023-06-13 | 2023-06-13 | Système de transport d'outil, procédé de commande d'un système de transport d'outil, et programme de commande d'un système de transport d'outil |
| JP2025526959A JPWO2024257220A1 (fr) | 2023-06-13 | 2023-06-13 |
Applications Claiming Priority (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| PCT/JP2023/021915 WO2024257220A1 (fr) | 2023-06-13 | 2023-06-13 | Système de transport d'outil, procédé de commande d'un système de transport d'outil, et programme de commande d'un système de transport d'outil |
Publications (1)
| Publication Number | Publication Date |
|---|---|
| WO2024257220A1 true WO2024257220A1 (fr) | 2024-12-19 |
Family
ID=93851491
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| PCT/JP2023/021915 Ceased WO2024257220A1 (fr) | 2023-06-13 | 2023-06-13 | Système de transport d'outil, procédé de commande d'un système de transport d'outil, et programme de commande d'un système de transport d'outil |
Country Status (2)
| Country | Link |
|---|---|
| JP (1) | JPWO2024257220A1 (fr) |
| WO (1) | WO2024257220A1 (fr) |
Citations (3)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JP2006326611A (ja) * | 2005-05-24 | 2006-12-07 | Murata Mach Ltd | 工具ホルダチェンジャー制御プログラム作成装置 |
| JP2022024520A (ja) * | 2020-07-28 | 2022-02-09 | Dmg森精機株式会社 | 工具セットアップ装置、工具セットアップ装置の制御方法、および工具セットアップ装置の制御プログラム |
| JP2022547677A (ja) * | 2019-09-16 | 2022-11-15 | デッケル マホ プフロンテン ゲーエムベーハー | 1又は2以上の工作機械で用いるためのロード又はアンロード装置及びロード又はアンロードシステム |
-
2023
- 2023-06-13 JP JP2025526959A patent/JPWO2024257220A1/ja active Pending
- 2023-06-13 WO PCT/JP2023/021915 patent/WO2024257220A1/fr not_active Ceased
Patent Citations (3)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JP2006326611A (ja) * | 2005-05-24 | 2006-12-07 | Murata Mach Ltd | 工具ホルダチェンジャー制御プログラム作成装置 |
| JP2022547677A (ja) * | 2019-09-16 | 2022-11-15 | デッケル マホ プフロンテン ゲーエムベーハー | 1又は2以上の工作機械で用いるためのロード又はアンロード装置及びロード又はアンロードシステム |
| JP2022024520A (ja) * | 2020-07-28 | 2022-02-09 | Dmg森精機株式会社 | 工具セットアップ装置、工具セットアップ装置の制御方法、および工具セットアップ装置の制御プログラム |
Also Published As
| Publication number | Publication date |
|---|---|
| JPWO2024257220A1 (fr) | 2024-12-19 |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| JP6775704B1 (ja) | 工具セットアップ装置、工具セットアップ装置の制御方法、および工具セットアップ装置の制御プログラム | |
| CN116133788B (zh) | 搬送系统、搬送系统的控制方法以及搬送系统的控制程序 | |
| JP7564234B2 (ja) | 工具搬送システム、工具搬送システムの制御方法、および、工具搬送システムの制御プログラム | |
| CN110244663A (zh) | 生产管理系统 | |
| JP6793278B1 (ja) | 工具搬送システム、工具搬送システムの制御方法、および、工具搬送システムの制御プログラム | |
| EP4249170A1 (fr) | Système de transport d'outils, procédé de commande pour système de transport d'outils et programme de commande pour système de transport d'outils | |
| WO2022185773A1 (fr) | Système de transport d'outils, procédé de commande de système de transport d'outils et programme de commande de système de transport d'outils | |
| JP7530520B2 (ja) | 工具搬送システム、制御方法、および制御プログラム | |
| JP6995458B1 (ja) | 工具搬送システム、工具搬送システムの制御方法、および工具搬送システムの制御プログラム | |
| JP7556183B1 (ja) | 工具管理装置、工具管理システム、工具ユニットの情報を管理する管理方法、および工具ユニットの情報を管理する管理プログラム | |
| JP7579994B2 (ja) | 搬送システム、制御方法、および制御プログラム | |
| JP7639138B2 (ja) | 加工システム、検索方法、および検索プログラム | |
| JP7001854B1 (ja) | 工具搬送システム、工具搬送システムの制御方法、および工具搬送システムの制御プログラム | |
| WO2024257218A1 (fr) | Système de transport d'outils, procédé de commande pour système de transport d'outils, et programme de commande pour système de transport d'outils |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| 121 | Ep: the epo has been informed by wipo that ep was designated in this application |
Ref document number: 23941528 Country of ref document: EP Kind code of ref document: A1 |
|
| ENP | Entry into the national phase |
Ref document number: 2025526959 Country of ref document: JP Kind code of ref document: A |
|
| WWE | Wipo information: entry into national phase |
Ref document number: 2025526959 Country of ref document: JP |
|
| NENP | Non-entry into the national phase |
Ref country code: DE |