EP4067202A1 - Procédé et agencement de localisation d'un véhicule guidé sur rails dans un réseau d'itinéraires après la mise en service du véhicule - Google Patents
Procédé et agencement de localisation d'un véhicule guidé sur rails dans un réseau d'itinéraires après la mise en service du véhicule Download PDFInfo
- Publication number
- EP4067202A1 EP4067202A1 EP21166402.4A EP21166402A EP4067202A1 EP 4067202 A1 EP4067202 A1 EP 4067202A1 EP 21166402 A EP21166402 A EP 21166402A EP 4067202 A1 EP4067202 A1 EP 4067202A1
- Authority
- EP
- European Patent Office
- Prior art keywords
- vehicle
- absolute
- route network
- computer
- image
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Granted
Links
Images


Classifications
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B61—RAILWAYS
- B61L—GUIDING RAILWAY TRAFFIC; ENSURING THE SAFETY OF RAILWAY TRAFFIC
- B61L25/00—Recording or indicating positions or identities of vehicles or trains or setting of track apparatus
- B61L25/02—Indicating or recording positions or identities of vehicles or trains
- B61L25/025—Absolute localisation, e.g. providing geodetic coordinates
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B61—RAILWAYS
- B61L—GUIDING RAILWAY TRAFFIC; ENSURING THE SAFETY OF RAILWAY TRAFFIC
- B61L27/00—Central railway traffic control systems; Trackside control; Communication systems specially adapted therefor
- B61L27/50—Trackside diagnosis or maintenance, e.g. software upgrades
- B61L27/57—Trackside diagnosis or maintenance, e.g. software upgrades for vehicles or trains, e.g. trackside supervision of train conditions
Definitions
- the invention relates to a method for locating a track-bound vehicle in a route network after the vehicle has been put into operation.
- the invention also relates to an arrangement for locating a track-bound vehicle in a route network after the vehicle has been put into operation.
- the invention relates to a computer program product and a provision device for this computer program product, the computer program product being equipped with program instructions for carrying out this method.
- the invention can be used in connection with a method for locating a rail vehicle that is automatically controlled by ATS (Automatic Train Supervision), in particular operated without a driver, for example a rail vehicle controlled by a CBTC train control and train protection system, with an on-board train control device and trackside train protection devices and with a localization unit for acquiring position values while the rail vehicle is in motion.
- ATS Automatic Train Supervision
- the on-board, automatic train control device of a rail-bound vehicle which is integrated into a monitoring system of an Automatic Train Control (ATC)
- ATC Automatic Train Control
- the vehicles are also maintained and parked in depots.
- the vehicles are equipped with an on-board train protection device that secures the vehicles in regular operation and can trigger braking if the safety limits are exceeded.
- Modern, radio-based systems also include a trackside device of the train protection system, which Train movements securely tracked via position reports received from the vehicles.
- An example is CBTC (Communication-Based Train Control).
- the vehicles (trains) and the train protection device should be switched off during decommissioning in order to save energy.
- the vehicles should be able to resume operation as quickly as possible in the most comfortable and therefore unrestricted operating mode (e.g. CTC, Continuous Train Control, without a fixed speed limit of 25 km/h).
- CTC Continuous Train Control
- the on-board train protection device is switched off, the safely measured and stored vehicle position is lost. This reliable location must be established by a cumbersome, driver-operated slow drive using location markers (balises) and driving in mode without a fixed speed limit is only possible again after a while, typically after 250 m or 1 to 2 minutes.
- the invention is based on the object of designing a method of the type specified at the outset in such a way that it can be used to quickly localize a rail vehicle with comparatively little effort.
- the object of the invention is to specify an arrangement, a computer program product and a device for providing such a product, with which the method can be carried out.
- At least one camera is used for localization, which takes a picture of the vehicle and at least one stationary optical marker whose absolute position in the route network is known, a relative one Vehicle position of the vehicle is determined for the stationary optical marker in the image and the absolute vehicle position of the vehicle in the route network is determined taking into account the absolute position of the marker and the relative position of the vehicle.
- a position of a rail-bound vehicle for example a local train such as a metro train in the depot, when it is started up.
- cameras are used according to the invention, which image stationary optical markers in the area surrounding the vehicle and the vehicle itself.
- the position of the vehicle relative to the stationary optical marker can thus be determined by image processing. Since the fixed optical marker (the fixed and mobile optical markers are also called markers for short below mentioned) cannot move in contrast to the vehicle, the absolute position of the vehicle in the route network, for example in the depot, can also be determined via the relative position of the vehicle to the marker.
- the localization of the vehicle according to the invention is inherently subject to measurement errors.
- a (per se known) locating normally provided for in the operating method of the vehicle must be carried out. This can be done, for example, by driving the vehicle over a balise installed in the track (more on this below).
- the method according to the invention has the advantage that the vehicle can be temporarily located before it is put into operation. Therefore, cost-intensive locating devices, which would enable an immediate precise localization of the vehicle, can be saved at the place where the method according to the invention is used (for example in a vehicle depot). On the other hand, the vehicle can be put into operation without the need for exclusively manual operation by a driver who would have to board the train for this purpose. Particularly in the case of driverless rail operations, this results in a considerable saving in personnel costs.
- the method according to the invention can also be used if a CMD is provided for the vehicle. If the CMD fails, there is then an alternative way of detecting a vehicle movement, so that manual driver operation can be dispensed with even if the CMD fails, because the method provides a second independent way of localization.
- mobile means that the position of the mobile object (for example a vehicle or a vehicle-bound mobile optical marker) can change.
- An absolute position is a position of an object (particularly vehicle, marker) in the global coordinate system.
- a relative position is to be understood as a position of an object in relation to another object (for example a vehicle in relation to a stationary optical marker).
- “computer-aided” or “computer-implemented” can be understood to mean an implementation of the method in which at least one computer executes at least one method step of the method.
- Computers covers all electronic devices with data processing properties.
- Computers can be, for example, personal computers, servers, handheld computers, mobile radio devices and other communication devices, processors and other electronic devices for data processing, which can preferably also be combined to form a network.
- a “processor” can be understood to mean, for example, a converter, a sensor for generating measurement signals, or an electronic circuit.
- a processor can in particular be a main processor (Central Processing Unit, CPU), a microprocessor, a microcontroller, or a digital signal processor, possibly in combination with a memory unit for storing program instructions, etc.
- CPU Central Processing Unit
- a processor can also be understood to mean a virtualized processor or a soft CPU.
- a “memory unit” can be, for example, a computer-readable memory in the form of a working memory (random-access memory, RAM) or data storage (hard disk or data carrier).
- RAM random-access memory
- data storage hard disk or data carrier
- the “interfaces” can be realized in terms of hardware, for example by cable or as a radio connection, or in terms of software, for example as an interaction between individual program modules of one or more computer programs.
- Program modules should be understood to mean individual functional sequences that enable a program sequence of computer-aided method steps according to the invention. These functional sequences can be implemented in a single computer program or in several computer programs that communicate with one another. The interfaces implemented here can be implemented in terms of software within a single processor or in terms of hardware if multiple processors are used.
- the method uses an output device to display the image and an input device to input the absolute vehicle position.
- the use of an output device and an input device advantageously makes it possible for the method to be partially carried out manually using operating personnel.
- the output device is preferably a screen that displays the recorded image.
- the input device is, for example, a keyboard or a control panel provided specifically for the purpose of input.
- the method uses an output device to display the image and an input device to enter the relative vehicle position, and the absolute vehicle position in the route network is determined with computer assistance, taking into account the absolute position of the stationary marker and the relative vehicle position.
- an employee can determine the position of the vehicle relative to one of several stationary markers. These markers can, for example, be numbered consecutively in order to be able to provisionally determine the position of the vehicle in a depot.
- the input device can then be used by the employee to enter a specific position of the vehicle in the route network.
- the output device and the input device can also be used when the position of the vehicle is determined with a higher degree of automation.
- the operating personnel can take on the role of a control authority since, as already mentioned, the position determination is less precise than would be the case in normal operation of the vehicle due to the ATC system that is used. This means that the operating personnel can intervene if obvious location errors occur.
- the relative vehicle position to the stationary marker in the image is determined with computer assistance and the absolute vehicle position in the route network is determined with computer assistance, taking into account the absolute position of the stationary marker and the relative vehicle position.
- the automated image interpretation advantageously increases the reproducibility of the position determination.
- the measurement errors that occur can also be narrowed down more precisely than with a human evaluation of the recorded image case is.
- malfunctions can occur that are not noticeable in an automatic position calculation. Therefore, an additional control by the operating staff is advantageous, which is however supported by the automatic position determination.
- the absolute vehicle position is used as preliminary location information for starting up the vehicle in a restricted operating mode and the preliminary location information is replaced by secure location information as soon as the vehicle has been detected by a location device equipped with a security level, and the secure location information is used after a transition from the restricted mode of operation to a normal mode of operation.
- the determined absolute vehicle position is used as preliminary location information for starting up the vehicle, it can also be started up if no vehicle position is known, which is usually used for the ATC system in operation.
- the vehicle Since there is greater uncertainty with regard to the location information used than in the normal operation of the vehicle, the vehicle is commissioned in a restricted operating mode, with the restrictions being provided for the prevention of malfunctions and accidents.
- the at least one camera is used at least once more for localization, which takes a picture of the vehicle and at least one stationary optical marker whose absolute position in the route network is known, a vehicle position of the vehicle relative to the stationary optical marker is determined in the image, the absolute vehicle position of the vehicle in the route network is determined taking into account the absolute position of the marker and the relative position of the vehicle.
- a repetition of the preliminary location procedure i. H. a method of location using the cameras, can confirm or correct the preliminary location information that is already available.
- the vehicle comes close to another stationary optical marker, it may be located with a smaller measurement error than was possible before it was put into operation.
- the optical and spatial conditions may not be optimal, so that the measurement uncertainties that have to be expected with a repeated position determination can be advantageously reduced.
- the localization step can be designed in the manner already described above (ie as in the first measurement).
- the vehicle's ATC system can determine, for example, how it can reach the nearest locating device as quickly as possible.
- the nearest locating device can reach at all.
- the locating device that is actually the shortest distance from the vehicle but cannot be reached by the vehicle can be located on the adjacent track because the adjacent track is being traveled on in the opposite direction, for example.
- the restricted operating mode is limited to a maximum speed that may be driven in the restricted operating mode, and/or is limited to a maximum distance that may be covered in the restricted operating mode.
- the permitted maximum speed for example 25 km/h, which in the restricted operating mode is of course lower than that in the normal operating mode, and also the permitted maximum route, which is preferably in an area of the route network that is separated from regular traffic, offer restrictions for the operating mode that improve operational safety Use of still inaccurate provisional location information can advantageously increase. It is also easier for the train staff to intervene manually in this way.
- the at least one camera is also used to record an image of a mobile optical marker of the vehicle that is attached to the vehicle and whose position on the vehicle is known.
- a mobile optical marker on the vehicle advantageously makes it possible to be able to better determine its position relative to a stationary optical marker.
- the mobile optical marker is much smaller compared to the entire vehicle and its position relative to the stationary optical marker can therefore be determined more easily. As a result, the determination of the absolute position becomes more precise and the implementation of the method is therefore more reliable.
- the stationary and/or mobile optical markers have a code made up of alphanumeric characters and/or a machine-readable code.
- alphanumeric character includes (at least) the letters of a given alphabet, as well as the ten digits from 0 to 9. In a broader sense, special characters (e.g. punctuation marks: period, comma, letters with diacritics, brackets, etc.) ) counted among the alphanumeric characters.
- Alphanumeric support can be given, for example, by numbering stationary optical markers in a depot or the like (and marking the markers with the numbers). Likewise, different vehicles can be provided with consecutive numbers on mobile optical markers. In the case of a manual evaluation, this makes it easier for the operating personnel to find their way around.
- a machine-readable coding advantageously facilitates the computer-aided evaluation of the recorded images.
- the coding can contain train numbers and location information of the stationary or mobile marker in question.
- the stationary and/or mobile optical markers have a position mark.
- Position markers enable a more precise determination of the location of the relevant fixed or mobile optical marker. This allows more accurate calculation or determination results to be obtained. Position markers can consist of crosses or circles, for example, and are smaller compared to the extent of the optical marker and can therefore be localized more precisely. These can also be contrasted in color so that they can be better recognized in poor lighting conditions.
- the stated object is also achieved according to the invention with the subject matter of the claim (arrangement) specified at the outset in that the arrangement has: at least one stationary optical marker of the arrangement whose absolute position in the route network is known, at least one camera that is set up by the vehicle and take an image of the stationary optical marker, a computer that is set up to control an output device for displaying the image and an input device for inputting the absolute vehicle position, and/or that is set up to calculate a relative vehicle position of the vehicle with the computer aided to the stationary optical marker To determine markers in the image and to determine the absolute vehicle position of the vehicle in the route network, taking into account the absolute position of the stationary optical marker and the relative position of the vehicle.
- a provision device for storing and/or providing the computer program product.
- the provision device is, for example, a storage unit that stores and/or provides the computer program product.
- the provision device is, for example, a network service, a computer system, a server system, in particular a distributed, for example cloud-based computer system and/or virtual computer system, which stores and/or provides the computer program product preferably in the form of a data stream.
- the provision takes place in the form of a program data block as a file, in particular as a download file, or as a data stream, in particular as a download data stream, of the computer program product.
- this provision can also be made, for example, as a partial download consisting of several parts.
- Such a computer program product is read into a system, for example using the provision device, so that the method according to the invention is executed on a computer.
- the described components of the embodiments each represent individual features of the invention to be considered independently of one another, which also develop the invention independently of one another and are therefore also to be regarded as part of the invention individually or in a combination other than the one shown. Furthermore, the components described can also be combined with the features of the invention described above.
- a vehicle FZ is shown in a depot DP.
- the vehicle FZ is on a track GL, in which a balise BL is installed outside the depot DP.
- control center LZ in which a computer CP is located.
- the control center LZ is radio-supported in a manner not shown in detail via a first interface S1 with a first camera CM1 in the depot DP, via a second interface S2 with a third camera CM3 and a fourth camera CM4 of the vehicle FZ and via a third interface S3 with a second camera CM2 connected outside the depot DP.
- the angles of view BW of the first camera CM1, the second camera CM2 and the third camera CM3 are in figure 1 implied.
- a first stationary optical marker OM1 and a second stationary optical marker OM2 which are set up on track GL and whose respective absolute position in the route network (represented by track GL) is known.
- the vehicle FZ has a mobile optical marker OMM, which thus moves together with the vehicle.
- the second stationary optical marker OM2 has a position mark PSM in the form of a plus sign, which enables better localization of the second stationary optical marker OM2 on an image recorded by the second camera CM2.
- This marker is identified by a machine-readable code MLC (in figure 1 displayed as a barcode, but also executable as a QR code). This information can be evaluated on the image recorded by the second camera CM2.
- MLC machine-readable code
- an alphanumeric two is also provided as an alphanumeric character ANZ on the marker, which can be seen on the image recorded by the second camera CM2, for example by operating personnel.
- the first stationary optical marker OM1 has the same structure.
- the barcode used there contains others Information, also an alphanumeric one is used.
- the first stationary optical marker OM1 can be recorded both by the camera CM3 located on the vehicle FZ and by the first camera CM1 permanently installed in the depot DP (cf. the indicated image angle BW).
- the mobile optical marker OMM on the vehicle FZ has a Zett as an alphanumeric character so that the operating personnel can see it as a train-related mobile optical marker.
- a barcode is also used here, which contains corresponding information about the vehicle FZ.
- An Ix is used as a position mark
- an employee BP of the operating staff can evaluate the images recorded by the cameras CM1, CM2, CM3 with the support of the computer CP in order to determine the position of the vehicle FZ in the depot DP before it is put into operation.
- the vehicle FZ can then be put into operation with the aid of this location information in order to drive in a restricted operating mode to the beacon BL and there to generate precise location information by crossing the beacon.
- Driving in the restricted operating mode and thus also the transition to the normal operating mode after crossing the balise can take place without a driver.
- the vehicle FZ is also preferably driving without a driver in the normal operating mode.
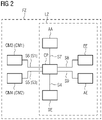
- figure 2 is the functional relationship of the individual components of the operating procedure figure 1 shown in more detail.
- the computer CP supports the method.
- the computer CP may be present in the control center LZ.
- dash-dotted lines indicate both the system boundaries when using the computer CP in the control center LZ and when using the computer CP in the vehicle FZ.
- the computing power of the computer CP is limited to several Processors can be distributed, which are distributed both in the control center LZ and in the vehicle FZ.
- a computer CP should be spoken of (in this case the dot-dash system boundaries LZ, FZ would not exist).
- the computer CP is connected to a storage device SE via a fourth interface S4.
- the memory device SE can contain the software required for carrying out the method, which is activated to carry out the method after the computer CP in the vehicle FZ, for example, has been started up.
- the memory device SE can also be used to store localization information that is calculated by the method.
- the computer CP is connected to the fourth camera CM4 via a fifth interface S5 and to the third camera CM3 via a sixth interface S6.
- the reference symbols given in brackets apply to accommodation of the computer CP in the control center LZ figure 2 , i.e. that as in figure 1 shown, the first camera CM1 is connected to the computer CP via the first interface S1 and the second camera CM2 is connected to the computer CP via the third interface S3.
- the computer CP is connected to an antenna arrangement AA via a seventh interface S7, which enables communication via radio interfaces, for example between the control center LZ and the vehicle FZ, but also, for example, between the vehicle FZ and the balise BL (the antenna arrangement can be different for this purpose have antennas).
- the computer CP is connected to an input unit EE via the eighth interface S8 and to an output unit AE via a ninth interface S9.
- the input unit EE enables the operating personnel to make entries in the manner already described, while the output device AE enables the images recorded by one of the cameras CM1 . . . CM4 to be displayed in particular.
- an activation step AKTV of the vehicle takes place.
- an image recording step PICT an image recording is generated by one of the cameras used.
- This can alternatively be output to the operating personnel via the ninth interface S9 using the output device AE in an output step OUT.
- This can estimate the relative position ESTM RPOS in a manual step and then enter the determined relative position into the computer CP through an input step IN using the eighth interface S8.
- the position of the vehicle relative to the marker imaged with the vehicle can be calculated.
- the absolute position ESTM APOS of the vehicle can be estimated manually by the operating personnel and in a subsequent input step IN the absolute position APOS can be entered into the computer CP using the input device EE via the eighth interface S8.
- the absolute position APOS can also be calculated by the computer CP in a calculation step CALC APOS.
- the absolute position APOS that is now available can be used to set the location information SET LOC in a next step. This is then available in the computer CP to start operation in the restricted operating mode MOD LIM of the vehicle. In this case, it is possible for the operating personnel to monitor operation in the restricted operating mode in a control step CRTL (for example by evaluating other images which are recorded with the relevant cameras). With this it is possible that the operating personnel intervene if operational disruptions or accidents are imminent.
- the vehicle while operating in the restricted operating mode MOD LIM, reaches a locating device for a more precise localization, which enables a detection step for the absolute position REC APOS, which, due to a higher localization accuracy, then sets the more precise location information SET again LOC enabled.
- the next step is to start operation in the normal MOD NRM operating mode. The procedure is stopped.
Landscapes
- Engineering & Computer Science (AREA)
- Mechanical Engineering (AREA)
- Health & Medical Sciences (AREA)
- Biomedical Technology (AREA)
- General Health & Medical Sciences (AREA)
- Train Traffic Observation, Control, And Security (AREA)
Priority Applications (3)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| ES21166402T ES3012357T3 (en) | 2021-03-31 | 2021-03-31 | Method and assembly for locating a track-bound vehicle in a route network following start-up of the vehicle |
| EP21166402.4A EP4067202B1 (fr) | 2021-03-31 | 2021-03-31 | Procédé et agencement de localisation d'un véhicule guidé sur rails dans un réseau d'itinéraires après la mise en service du véhicule |
| CN202210305623.4A CN115140124B (zh) | 2021-03-31 | 2022-03-25 | 在车辆起动后在路网中定位轨道导引的车辆的方法和装置 |
Applications Claiming Priority (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| EP21166402.4A EP4067202B1 (fr) | 2021-03-31 | 2021-03-31 | Procédé et agencement de localisation d'un véhicule guidé sur rails dans un réseau d'itinéraires après la mise en service du véhicule |
Publications (3)
| Publication Number | Publication Date |
|---|---|
| EP4067202A1 true EP4067202A1 (fr) | 2022-10-05 |
| EP4067202C0 EP4067202C0 (fr) | 2024-11-20 |
| EP4067202B1 EP4067202B1 (fr) | 2024-11-20 |
Family
ID=75339610
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| EP21166402.4A Active EP4067202B1 (fr) | 2021-03-31 | 2021-03-31 | Procédé et agencement de localisation d'un véhicule guidé sur rails dans un réseau d'itinéraires après la mise en service du véhicule |
Country Status (3)
| Country | Link |
|---|---|
| EP (1) | EP4067202B1 (fr) |
| CN (1) | CN115140124B (fr) |
| ES (1) | ES3012357T3 (fr) |
Cited By (4)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| DE102023210683A1 (de) * | 2023-10-27 | 2025-04-30 | Siemens Mobility GmbH | Positionsbestimmung eines Schienenfahrzeuges |
| EP4671084A1 (fr) | 2024-06-28 | 2025-12-31 | Siemens Mobility GmbH | Procédé de détermination de la vitesse d'un véhicule guidé se déplaçant sur un trajet |
| EP4671083A1 (fr) | 2024-06-28 | 2025-12-31 | Siemens Mobility GmbH | Procédé de localisation d'un véhicule guidé sur rails |
| EP4696583A1 (fr) | 2024-08-16 | 2026-02-18 | Siemens Mobility GmbH | Procédé de détermination de la vitesse d'un véhicule guidé se déplaçant sur un trajet |
Citations (5)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| KR20130108715A (ko) * | 2012-03-26 | 2013-10-07 | 한국철도기술연구원 | 영상을 이용한 철도차량의 위치검지 시스템 및 위치검지방법 |
| DE102014226045A1 (de) * | 2014-12-16 | 2016-06-16 | Siemens Aktiengesellschaft | Verfahren und Vorrichtung zur relativenZuglagenbestimmung zweier Züge |
| DE102015207223A1 (de) | 2015-04-21 | 2016-10-27 | Siemens Aktiengesellschaft | Verfahren und Anordnung zum Lokalisieren eines in einem CBTC (Communication-Based Train Control)-Zugsteuerungs- und Zugsicherungssystems verkehrenden Schienenfahrzeugs |
| EP3024713B1 (fr) | 2013-09-10 | 2018-01-03 | Siemens Aktiengesellschaft | Procédé et dispositif de détection d'un changement de position d'un véhicule au moins partiellement arrêté |
| EP3415400A1 (fr) * | 2017-06-12 | 2018-12-19 | Siemens Aktiengesellschaft | Système et procédé de mesure de la position d'un véhicule guidé |
Family Cites Families (6)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| DE4012668A1 (de) * | 1990-04-20 | 1991-10-31 | W & M Engineering & Automation | Rocar-steuerung |
| CN103693078B (zh) * | 2013-12-18 | 2015-11-18 | 北京大成通号轨道交通设备有限公司 | 目标距离模式的列车自动防护方法 |
| DE102014212629A1 (de) * | 2014-06-30 | 2015-12-31 | Siemens Aktiengesellschaft | Verfahren zum Betreiben eines Schienenfahrzeugs |
| DE102014218761A1 (de) * | 2014-09-18 | 2016-03-24 | Siemens Aktiengesellschaft | Verfahren und Vorrichtung zur Stillstandsüberwachung |
| CN110325425A (zh) * | 2016-12-07 | 2019-10-11 | 西门子交通有限责任公司 | 用于铁路交通中的车道识别、尤其用于轨道交通中的铁轨识别的方法、设备和铁路车辆、尤其轨道车辆 |
| CN111914691B (zh) * | 2020-07-15 | 2024-03-19 | 北京埃福瑞科技有限公司 | 一种轨道交通车辆定位方法及系统 |
-
2021
- 2021-03-31 EP EP21166402.4A patent/EP4067202B1/fr active Active
- 2021-03-31 ES ES21166402T patent/ES3012357T3/es active Active
-
2022
- 2022-03-25 CN CN202210305623.4A patent/CN115140124B/zh active Active
Patent Citations (5)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| KR20130108715A (ko) * | 2012-03-26 | 2013-10-07 | 한국철도기술연구원 | 영상을 이용한 철도차량의 위치검지 시스템 및 위치검지방법 |
| EP3024713B1 (fr) | 2013-09-10 | 2018-01-03 | Siemens Aktiengesellschaft | Procédé et dispositif de détection d'un changement de position d'un véhicule au moins partiellement arrêté |
| DE102014226045A1 (de) * | 2014-12-16 | 2016-06-16 | Siemens Aktiengesellschaft | Verfahren und Vorrichtung zur relativenZuglagenbestimmung zweier Züge |
| DE102015207223A1 (de) | 2015-04-21 | 2016-10-27 | Siemens Aktiengesellschaft | Verfahren und Anordnung zum Lokalisieren eines in einem CBTC (Communication-Based Train Control)-Zugsteuerungs- und Zugsicherungssystems verkehrenden Schienenfahrzeugs |
| EP3415400A1 (fr) * | 2017-06-12 | 2018-12-19 | Siemens Aktiengesellschaft | Système et procédé de mesure de la position d'un véhicule guidé |
Cited By (4)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| DE102023210683A1 (de) * | 2023-10-27 | 2025-04-30 | Siemens Mobility GmbH | Positionsbestimmung eines Schienenfahrzeuges |
| EP4671084A1 (fr) | 2024-06-28 | 2025-12-31 | Siemens Mobility GmbH | Procédé de détermination de la vitesse d'un véhicule guidé se déplaçant sur un trajet |
| EP4671083A1 (fr) | 2024-06-28 | 2025-12-31 | Siemens Mobility GmbH | Procédé de localisation d'un véhicule guidé sur rails |
| EP4696583A1 (fr) | 2024-08-16 | 2026-02-18 | Siemens Mobility GmbH | Procédé de détermination de la vitesse d'un véhicule guidé se déplaçant sur un trajet |
Also Published As
| Publication number | Publication date |
|---|---|
| ES3012357T3 (en) | 2025-04-09 |
| CN115140124B (zh) | 2023-11-24 |
| CN115140124A (zh) | 2022-10-04 |
| EP4067202C0 (fr) | 2024-11-20 |
| EP4067202B1 (fr) | 2024-11-20 |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| EP4067202B1 (fr) | Procédé et agencement de localisation d'un véhicule guidé sur rails dans un réseau d'itinéraires après la mise en service du véhicule | |
| EP2250065B1 (fr) | Procédé de sécurisation de véhicules sur rails par des techniques de signalisation et système de sécurisation de ces véhicules | |
| DE10104946B4 (de) | Verfahren und Vorrichtung zur Bestimmung der aktuellen Position und zur Überwachung des geplanten Weges eines Objektes | |
| EP4077098A1 (fr) | Procédé et système de surveillance pour déterminer une position d'un véhicule ferroviaire | |
| DE102015210427A1 (de) | Verfahren sowie Einrichtung zum Ermitteln einer Fahrerlaubnis für ein spurgebundenes Fahrzeug | |
| EP2085287A1 (fr) | Procédé de détermination automatisée et réglage de paramètres d'alerte dans des véhicules sur rails et système correspondant | |
| EP3526097A1 (fr) | Procédé, dispositif et véhicule sur voie, en particulier véhicule ferroviaire, pour la détection de voie en matière de trafic sur voie, en particulier pour la détection de voie ferrée en matière de trafic ferroviaire | |
| EP4126633B1 (fr) | Procédé de surveillance de la position d'un véhicule ferroviaire en stationnement, et programme informatique, en particulier pour un système de sécurité de train | |
| WO2014044541A2 (fr) | Commande de véhicules ferroviaires | |
| DE102004057545A1 (de) | Verfahren zum automatischen Erkennen einer Zugtrennung | |
| EP3795451B1 (fr) | Procédé de localisation d'un véhicule dans une station destinée à un arrêt du véhicule | |
| DE102014212629A1 (de) | Verfahren zum Betreiben eines Schienenfahrzeugs | |
| EP4640515A1 (fr) | Procédé de détermination de la position d'un véhicule guidé | |
| EP1935749B1 (fr) | Procédé et système de localisation d'un véhicule sur rail | |
| EP4124540A1 (fr) | Procédé et dispositif permettant de faire fonctionner un arrêt automatique pour un véhicule guidé sur rails | |
| AT413810B (de) | Einrichtung zur steuerung der fahrzeuge in einer gleisanlage | |
| DE102018215697A1 (de) | Automatisiertes fahrzeugseitiges Steuerungssystem für ein Schienenfahrzeug | |
| DE102020206005A1 (de) | Fahrbetriebsanordnung und Verfahren zum Steuern eines Schienenfahrzeugs | |
| WO2020239372A1 (fr) | Procédé pour faire fonctionner un véhicule sur rails | |
| EP3458333B1 (fr) | Procédé et dispositif de détermination d'une longueur d'un véhicule guidé sur rails | |
| DE202019102812U1 (de) | System zum kontrollierten Abbremsen und positionsdefinierten Stoppen eines Schienenfahrzeugs | |
| DE102014206779A1 (de) | Verfahren und Vorrichtung zur Stillstandsüberwachung bei Schienenfahrzeugen | |
| EP2849985A1 (fr) | Détermination de la position de véhicules ferroviaires | |
| WO1996021590A1 (fr) | Procede et systeme pour la collecte, le traitement et la visualisation en matiere de securite de donnees concernant l'etat d'installations de commande non centrales/centrales montees dans des vehicules moteurs | |
| DE2739231C3 (de) | Einrichtung zur Eigenortung spurgebundener Fahrzeuge |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| PUAI | Public reference made under article 153(3) epc to a published international application that has entered the european phase |
Free format text: ORIGINAL CODE: 0009012 |
|
| STAA | Information on the status of an ep patent application or granted ep patent |
Free format text: STATUS: THE APPLICATION HAS BEEN PUBLISHED |
|
| AK | Designated contracting states |
Kind code of ref document: A1 Designated state(s): AL AT BE BG CH CY CZ DE DK EE ES FI FR GB GR HR HU IE IS IT LI LT LU LV MC MK MT NL NO PL PT RO RS SE SI SK SM TR |
|
| STAA | Information on the status of an ep patent application or granted ep patent |
Free format text: STATUS: REQUEST FOR EXAMINATION WAS MADE |
|
| 17P | Request for examination filed |
Effective date: 20230403 |
|
| RBV | Designated contracting states (corrected) |
Designated state(s): AL AT BE BG CH CY CZ DE DK EE ES FI FR GB GR HR HU IE IS IT LI LT LU LV MC MK MT NL NO PL PT RO RS SE SI SK SM TR |
|
| GRAP | Despatch of communication of intention to grant a patent |
Free format text: ORIGINAL CODE: EPIDOSNIGR1 |
|
| STAA | Information on the status of an ep patent application or granted ep patent |
Free format text: STATUS: GRANT OF PATENT IS INTENDED |
|
| RIC1 | Information provided on ipc code assigned before grant |
Ipc: B61L 27/57 20220101ALI20240701BHEP Ipc: B61L 25/02 20060101AFI20240701BHEP |
|
| INTG | Intention to grant announced |
Effective date: 20240722 |
|
| GRAS | Grant fee paid |
Free format text: ORIGINAL CODE: EPIDOSNIGR3 |
|
| GRAA | (expected) grant |
Free format text: ORIGINAL CODE: 0009210 |
|
| STAA | Information on the status of an ep patent application or granted ep patent |
Free format text: STATUS: THE PATENT HAS BEEN GRANTED |
|
| AK | Designated contracting states |
Kind code of ref document: B1 Designated state(s): AL AT BE BG CH CY CZ DE DK EE ES FI FR GB GR HR HU IE IS IT LI LT LU LV MC MK MT NL NO PL PT RO RS SE SI SK SM TR |
|
| REG | Reference to a national code |
Ref country code: GB Ref legal event code: FG4D Free format text: NOT ENGLISH |
|
| REG | Reference to a national code |
Ref country code: CH Ref legal event code: EP |
|
| REG | Reference to a national code |
Ref country code: DE Ref legal event code: R096 Ref document number: 502021005838 Country of ref document: DE |
|
| REG | Reference to a national code |
Ref country code: IE Ref legal event code: FG4D Free format text: LANGUAGE OF EP DOCUMENT: GERMAN |
|
| U01 | Request for unitary effect filed |
Effective date: 20241203 |
|
| U07 | Unitary effect registered |
Designated state(s): AT BE BG DE DK EE FI FR IT LT LU LV MT NL PT RO SE SI Effective date: 20241212 |
|
| REG | Reference to a national code |
Ref country code: ES Ref legal event code: FG2A Ref document number: 3012357 Country of ref document: ES Kind code of ref document: T3 Effective date: 20250409 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: IS Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20250320 Ref country code: HR Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20241120 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: NO Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20250220 |
|
| U20 | Renewal fee for the european patent with unitary effect paid |
Year of fee payment: 5 Effective date: 20250320 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: GR Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20250221 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: PL Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20241120 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: RS Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20250220 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: SM Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20241120 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: SK Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20241120 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: CZ Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20241120 |
|
| PLBE | No opposition filed within time limit |
Free format text: ORIGINAL CODE: 0009261 |
|
| STAA | Information on the status of an ep patent application or granted ep patent |
Free format text: STATUS: NO OPPOSITION FILED WITHIN TIME LIMIT |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: MC Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20241120 |
|
| 26N | No opposition filed |
Effective date: 20250821 |
|
| REG | Reference to a national code |
Ref country code: CH Ref legal event code: H13 Free format text: ST27 STATUS EVENT CODE: U-0-0-H10-H13 (AS PROVIDED BY THE NATIONAL OFFICE) Effective date: 20251023 |
|
| U1H | Name or address of the proprietor changed after the registration of the unitary effect |
Owner name: SIEMENS MOBILITY GMBH; DE |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: CH Free format text: LAPSE BECAUSE OF NON-PAYMENT OF DUE FEES Effective date: 20250331 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: IE Free format text: LAPSE BECAUSE OF NON-PAYMENT OF DUE FEES Effective date: 20250331 |
|
| U20 | Renewal fee for the european patent with unitary effect paid |
Year of fee payment: 6 Effective date: 20260320 |
|
| PG25 | Lapsed in a contracting state [announced via postgrant information from national office to epo] |
Ref country code: CY Free format text: LAPSE BECAUSE OF FAILURE TO SUBMIT A TRANSLATION OF THE DESCRIPTION OR TO PAY THE FEE WITHIN THE PRESCRIBED TIME-LIMIT Effective date: 20241120 |
|
| PGFP | Annual fee paid to national office [announced via postgrant information from national office to epo] |
Ref country code: ES Payment date: 20260622 Year of fee payment: 6 |
|
| PGFP | Annual fee paid to national office [announced via postgrant information from national office to epo] |
Ref country code: GB Payment date: 20260402 Year of fee payment: 6 |