JP2007283221A - 搬送システムおよび加工設備 - Google Patents
搬送システムおよび加工設備 Download PDFInfo
- Publication number
- JP2007283221A JP2007283221A JP2006113920A JP2006113920A JP2007283221A JP 2007283221 A JP2007283221 A JP 2007283221A JP 2006113920 A JP2006113920 A JP 2006113920A JP 2006113920 A JP2006113920 A JP 2006113920A JP 2007283221 A JP2007283221 A JP 2007283221A
- Authority
- JP
- Japan
- Prior art keywords
- workpiece
- link body
- holding unit
- transport
- painting
- Prior art date
- Legal status (The legal status is an assumption and is not a legal conclusion. Google has not performed a legal analysis and makes no representation as to the accuracy of the status listed.)
- Granted
Links
Images





Classifications
-
- F—MECHANICAL ENGINEERING; LIGHTING; HEATING; WEAPONS; BLASTING
- F04—POSITIVE - DISPLACEMENT MACHINES FOR LIQUIDS; PUMPS FOR LIQUIDS OR ELASTIC FLUIDS
- F04B—POSITIVE-DISPLACEMENT MACHINES FOR LIQUIDS; PUMPS
- F04B49/00—Control, e.g. of pump delivery, or pump pressure of, or safety measures for, machines, pumps, or pumping installations, not otherwise provided for, or of interest apart from, groups F04B1/00 - F04B47/00
- F04B49/08—Regulating by delivery pressure
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B05—SPRAYING OR ATOMISING IN GENERAL; APPLYING FLUENT MATERIALS TO SURFACES, IN GENERAL
- B05B—SPRAYING APPARATUS; ATOMISING APPARATUS; NOZZLES
- B05B13/00—Machines or plants for applying liquids or other fluent materials to surfaces of objects or other work by spraying, not covered by groups B05B1/00 - B05B11/00
- B05B13/02—Means for supporting work; Arrangement or mounting of spray heads; Adaptation or arrangement of means for feeding work
- B05B13/0221—Means for supporting work; Arrangement or mounting of spray heads; Adaptation or arrangement of means for feeding work characterised by the means for moving or conveying the objects or other work, e.g. conveyor belts
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B05—SPRAYING OR ATOMISING IN GENERAL; APPLYING FLUENT MATERIALS TO SURFACES, IN GENERAL
- B05B—SPRAYING APPARATUS; ATOMISING APPARATUS; NOZZLES
- B05B13/00—Machines or plants for applying liquids or other fluent materials to surfaces of objects or other work by spraying, not covered by groups B05B1/00 - B05B11/00
- B05B13/02—Means for supporting work; Arrangement or mounting of spray heads; Adaptation or arrangement of means for feeding work
- B05B13/0221—Means for supporting work; Arrangement or mounting of spray heads; Adaptation or arrangement of means for feeding work characterised by the means for moving or conveying the objects or other work, e.g. conveyor belts
- B05B13/0242—Means for supporting work; Arrangement or mounting of spray heads; Adaptation or arrangement of means for feeding work characterised by the means for moving or conveying the objects or other work, e.g. conveyor belts the objects being individually presented to the spray heads by a rotating element, e.g. turntable
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B05—SPRAYING OR ATOMISING IN GENERAL; APPLYING FLUENT MATERIALS TO SURFACES, IN GENERAL
- B05B—SPRAYING APPARATUS; ATOMISING APPARATUS; NOZZLES
- B05B13/00—Machines or plants for applying liquids or other fluent materials to surfaces of objects or other work by spraying, not covered by groups B05B1/00 - B05B11/00
- B05B13/02—Means for supporting work; Arrangement or mounting of spray heads; Adaptation or arrangement of means for feeding work
- B05B13/04—Means for supporting work; Arrangement or mounting of spray heads; Adaptation or arrangement of means for feeding work the spray heads being moved during spraying operation
- B05B13/0431—Means for supporting work; Arrangement or mounting of spray heads; Adaptation or arrangement of means for feeding work the spray heads being moved during spraying operation with spray heads moved by robots or articulated arms, e.g. for applying liquid or other fluent material to three-dimensional [3D] surfaces
-
- B—PERFORMING OPERATIONS; TRANSPORTING
- B25—HAND TOOLS; PORTABLE POWER-DRIVEN TOOLS; MANIPULATORS
- B25J—MANIPULATORS; CHAMBERS PROVIDED WITH MANIPULATION DEVICES
- B25J9/00—Program-controlled manipulators
- B25J9/0096—Program-controlled manipulators co-operating with a working support, e.g. work-table
Landscapes
- Engineering & Computer Science (AREA)
- Robotics (AREA)
- Mechanical Engineering (AREA)
- General Engineering & Computer Science (AREA)
- Spray Control Apparatus (AREA)
- Manipulator (AREA)
- Multi-Process Working Machines And Systems (AREA)
- Intermediate Stations On Conveyors (AREA)
- Threshing Machine Elements (AREA)
- Apparatuses For Bulk Treatment Of Fruits And Vegetables And Apparatuses For Preparing Feeds (AREA)
- Control Of Conveyors (AREA)
Abstract
【課題】 設置スペースを低減するとともに、作業性を向上することができる搬送システムを提供することである。
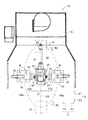
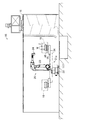
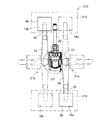
【解決手段】 搬送装置21a,21bは、搬送基部33に対して第1リンク体34を相対回転させるとともに、第1リンク体43に対して第2リンク体35を相対回転させることで、保持部40を搭載位置18と塗装位置19との間を略円弧状の軌跡に沿って移動させることができる。リンク機構を有する搬送装置によってワークWを搬送することによって、加工架台22を中心とする仮想円200よりも架台22寄りの移動経路に沿ってワークWを搬送させることができ、設置スペースの増加を抑えることができる。またワークWを略円弧状の移動経路100に沿って移動させることで、架台架台22に対してまわりこむようにワークWを移動させることができ、各搬送装置21a,21bの搭載位置18および塗装位置19とを可及的に近接させることができ、作業性を向上することができる。
【選択図】 図1
Description
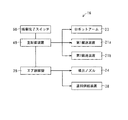
加工領域と搭載領域とを結ぶ第1移動経路であって、加工領域と搭載領域との中間で架台から離間する方向に膨らむ略円弧状の第1移動経路に沿って、ワークを搬送する第1搬送装置と、
架台からみて第1移動経路と反対側で、加工領域と搭載領域とを結ぶ第2移動経路であって、加工領域と搭載領域との中間で架台から離間する方向に膨らむ略円弧状の第2移動経路に沿って、ワークを搬送する第2搬送装置とを含み、
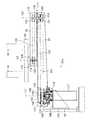
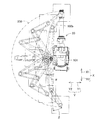
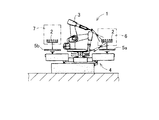
各搬送装置は、基部と、第1リンク体と、第2リンク体と、互いに相対回転可能に第1リンク体と基部とを連結する第1関節部と、互いに相対回転可能に第1リンク体と第2リンク体とを連結する第2関節部と、第2リンク体に設けられてワークを支持可能に構成され、前記移動経路に沿って移動駆動される保持部とを備えることを特徴とする搬送システムである。
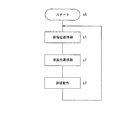
各搬送装置は、駆動力を与えて保持部を移動経路に沿って移動駆動する保持部移動状態と、駆動力を与えて保持部を自転回転する保持部回転状態とに、駆動力の伝達を切換える切換機構をさらに有することを特徴とする。
加工装置は、搬送システムによって加工領域に移動されるワークに塗料を噴射することを特徴とする加工設備である。
18 搭載位置
19 塗装位置
20 塗装装置
21 搬送システム
21a 第1搬送装置
21b 第2搬送装置
34 第1リンク体
35 第2リンク体
40 保持部
100a 第1移動経路
100b 第2移動経路
Claims (7)
- 加工装置によってワークが加工される加工領域と、加工装置が設置される架台からみて加工領域と略反対側に位置する搭載領域とにわたってワークを搬送する搬送システムであって、
加工領域と搭載領域とを結ぶ第1移動経路であって、加工領域と搭載領域との中間で架台から離間する方向に膨らむ略円弧状の第1移動経路に沿って、ワークを搬送する第1搬送装置と、
架台からみて第1移動経路と反対側で、加工領域と搭載領域とを結ぶ第2移動経路であって、加工領域と搭載領域との中間で架台から離間する方向に膨らむ略円弧状の第2移動経路に沿って、ワークを搬送する第2搬送装置とを含み、
各搬送装置は、基部と、第1リンク体と、第2リンク体と、互いに相対回転可能に第1リンク体と基部とを連結する第1関節部と、互いに相対回転可能に第1リンク体と第2リンク体とを連結する第2関節部と、第2リンク体に設けられてワークを支持可能に構成され、前記移動経路に沿って移動駆動される保持部とを備えることを特徴とする搬送システム。 - 各搬送装置は、互いに独立してワークを搬送可能に構成されることを特徴とする請求項1記載の搬送システム。
- 各搬送装置の保持部は、加工領域に設定される共通の加工位置に移動可能に構成されることを特徴とする請求項1または2記載の搬送システム。
- 各搬送装置の保持部は、搭載領域に設定される共通の搭載位置に移動可能に構成されることを特徴とする請求項1〜3のいずれか1つに記載の搬送システム。
- 各搬送装置は、基部に対する第1リンク体の回転変位に連動させて、第1リンク体に対して第2リンク体を回転変位させる連動機構をさらに有し、基部に対して第1リンク体を回転駆動することで、連動機構によって保持部を前記移動経路に沿って移動駆動することを特徴とする請求項1〜4のいずれか1つに記載の搬送システム。
- 各搬送装置の保持部は、加工領域に移動した状態で自転回転可能に構成され、
各搬送装置は、駆動力を与えて保持部を移動経路に沿って移動駆動する保持部移動状態と、駆動力を与えて保持部を自転回転する保持部回転状態とに、駆動力の伝達を切換える切換機構をさらに有することを特徴とする請求項1〜5のいずれか1つに記載の搬送システム。 - 請求項1〜6のいずれか1つに記載の搬送システムと、加工装置とを含み、
加工装置は、搬送システムによって加工領域に移動されるワークに塗料を噴射することを特徴とする加工設備。
Priority Applications (5)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| JP2006113920A JP5044138B2 (ja) | 2006-04-17 | 2006-04-17 | 搬送システムおよび加工設備 |
| US11/783,562 US7900578B2 (en) | 2006-04-17 | 2007-04-10 | Carrying system and processing equipment |
| DE602007013141T DE602007013141D1 (de) | 2006-04-17 | 2007-04-13 | Fördersystem und Verarbeitungsanlage |
| AT07106152T ATE501793T1 (de) | 2006-04-17 | 2007-04-13 | Fördersystem und verarbeitungsanlage |
| EP07106152A EP1870166B1 (en) | 2006-04-17 | 2007-04-13 | Carrying system and processing equipment |
Applications Claiming Priority (1)
| Application Number | Priority Date | Filing Date | Title |
|---|---|---|---|
| JP2006113920A JP5044138B2 (ja) | 2006-04-17 | 2006-04-17 | 搬送システムおよび加工設備 |
Publications (2)
| Publication Number | Publication Date |
|---|---|
| JP2007283221A true JP2007283221A (ja) | 2007-11-01 |
| JP5044138B2 JP5044138B2 (ja) | 2012-10-10 |
Family
ID=38605006
Family Applications (1)
| Application Number | Title | Priority Date | Filing Date |
|---|---|---|---|
| JP2006113920A Expired - Fee Related JP5044138B2 (ja) | 2006-04-17 | 2006-04-17 | 搬送システムおよび加工設備 |
Country Status (5)
| Country | Link |
|---|---|
| US (1) | US7900578B2 (ja) |
| EP (1) | EP1870166B1 (ja) |
| JP (1) | JP5044138B2 (ja) |
| AT (1) | ATE501793T1 (ja) |
| DE (1) | DE602007013141D1 (ja) |
Cited By (6)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JP2015044638A (ja) * | 2013-08-27 | 2015-03-12 | 川崎重工業株式会社 | ワーク搬送装置 |
| JP2018103117A (ja) * | 2016-12-27 | 2018-07-05 | ダイハツ工業株式会社 | 塗装ブース |
| KR102199834B1 (ko) * | 2020-06-22 | 2021-01-07 | 우태광 | 도장 시스템 |
| CN112892969A (zh) * | 2021-01-18 | 2021-06-04 | 日照中意华坤金属制造有限公司 | 一种铁艺制品加工用喷漆装置及工艺 |
| WO2025206140A1 (ja) * | 2024-03-28 | 2025-10-02 | 川崎重工業株式会社 | 塗装システム |
| JP7833226B1 (ja) * | 2025-06-06 | 2026-03-19 | コネクテッドロボティクス株式会社 | 保持システム、及びプログラム |
Families Citing this family (20)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| DE102006047382B4 (de) * | 2006-10-06 | 2011-03-17 | Venjakob Maschinenbau Gmbh & Co. Kg | Vorrichtung zum Lackieren von Werkstücken |
| ITRN20090015A1 (it) * | 2009-04-03 | 2010-10-04 | Alberto Mario Lucarelli | Macchina per movimentare un pannello destinato a lavorazioni superficiali |
| IT1395567B1 (it) * | 2009-08-28 | 2012-10-16 | Grossi S R L | Dispositivo per la verniciatura di pannelli |
| DE102009060649A1 (de) * | 2009-12-22 | 2011-06-30 | EISENMANN Anlagenbau GmbH & Co. KG, 71032 | Anlage zur Oberflächenbehandlung von Gegenständen |
| US20110171390A1 (en) * | 2010-01-08 | 2011-07-14 | United Technologies Corporation One Financial Plaza | Fixture for coating application |
| DE102010032144A1 (de) * | 2010-07-24 | 2012-01-26 | Eisenmann Ag | Behandlungseinheit und Anlage zur Oberflächenbehandlung von Gegenständen |
| DE102011100690A1 (de) * | 2011-05-05 | 2012-11-08 | Asis Gmbh | Verfahren und Vorrichtung zum Lackieren |
| WO2013030958A1 (ja) * | 2011-08-30 | 2013-03-07 | 株式会社安川電機 | 搬送装置およびロボットシステム |
| JP5549702B2 (ja) * | 2012-04-03 | 2014-07-16 | 株式会社安川電機 | 搬送装置およびロボットシステム |
| US8997438B1 (en) * | 2012-09-18 | 2015-04-07 | David M. Fallas | Case packing system having robotic pick and place mechanism and dual dump bins |
| JP2015100761A (ja) * | 2013-11-26 | 2015-06-04 | 曙ブレーキ工業株式会社 | 支持具、粉体塗布システム、粉体塗布方法、及びキャリパ |
| JP6774633B2 (ja) * | 2017-07-20 | 2020-10-28 | 株式会社安川電機 | ロボットシステム |
| CN108568374A (zh) * | 2017-12-05 | 2018-09-25 | 湖南飞沃新能源科技股份有限公司 | 一种达克罗喷涂生产系统 |
| CN108380425A (zh) * | 2018-06-14 | 2018-08-10 | 东莞市隆盛智能装备有限公司 | 一种伺服连杆喷雾机 |
| CN110484835B (zh) * | 2019-09-05 | 2020-12-15 | 马鞍山海华耐磨材料科技有限公司 | 一种耐磨高锰钢锤头的生产工艺 |
| JP7136067B2 (ja) * | 2019-11-27 | 2022-09-13 | 株式会社安川電機 | ロボットシステム |
| JP7551366B2 (ja) | 2020-07-13 | 2024-09-17 | 川崎重工業株式会社 | 搬送装置及びロボットシステム |
| EP4026662A1 (en) * | 2021-01-11 | 2022-07-13 | Robotautomation Svenska AB | Object transfer device and a robot system including the object transfer device |
| US11826768B2 (en) * | 2021-03-11 | 2023-11-28 | Ford Global Technologies, Llc | Method and apparatus for adaptive control and real-time edge tracking of adhesive and sealer dispensing |
| CN119140322B (zh) * | 2024-11-14 | 2025-04-01 | 江苏向利防静电装饰材料股份有限公司 | 一种全钢地板的金属皮表层防腐蚀加工设备 |
Citations (7)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JPS6179585A (ja) * | 1984-09-28 | 1986-04-23 | ぺんてる株式会社 | ダブルア−ム型ロボツト |
| JPH01281891A (ja) * | 1988-04-30 | 1989-11-13 | Tokico Ltd | 工業用ロボット装置 |
| JPH0283056A (ja) * | 1988-09-20 | 1990-03-23 | Tokico Ltd | 工業用ロボットへのワーク供給装置 |
| JPH10329178A (ja) * | 1997-06-02 | 1998-12-15 | Souki Sekkei:Kk | 射出成形品取出装置 |
| JP2002362738A (ja) * | 2001-06-04 | 2002-12-18 | Jel:Kk | 搬送アーム |
| JP2004217375A (ja) * | 2003-01-15 | 2004-08-05 | Kawasaki Heavy Ind Ltd | 搬送装置および加工設備 |
| JP2004291112A (ja) * | 2003-03-26 | 2004-10-21 | Hitachi Kiden Kogyo Ltd | 移載機 |
Family Cites Families (9)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| US4644897A (en) | 1985-10-01 | 1987-02-24 | Graco Robotics, Inc. | Modular robotic finishing work center |
| US4764077A (en) * | 1986-04-18 | 1988-08-16 | Thermwood Corporation | Assembly for performing work functions on a workpiece |
| JPH04200760A (ja) | 1990-11-30 | 1992-07-21 | Iwata Air Compressor Mfg Co Ltd | ロボット塗装用搬送装置 |
| JPH08118267A (ja) | 1994-10-18 | 1996-05-14 | M Alpha Giken:Kk | 搬送ロボット |
| US5765444A (en) * | 1995-07-10 | 1998-06-16 | Kensington Laboratories, Inc. | Dual end effector, multiple link robot arm system with corner reacharound and extended reach capabilities |
| US6491491B1 (en) * | 1997-10-30 | 2002-12-10 | Sankyo Seiki Mfg. Co., Ltd. | Articulated robot |
| JP4282800B2 (ja) | 1998-12-01 | 2009-06-24 | 川崎重工業株式会社 | ワーク搬送装置 |
| DE29909047U1 (de) | 1999-05-22 | 2000-11-23 | KUKA Schweissanlagen GmbH, 86165 Augsburg | Positioniervorrichtung für Werkstückträger oder Werkstücke |
| DE202004017881U1 (de) | 2004-11-17 | 2006-03-23 | Kuka Schweissanlagen Gmbh | Handlingvorrichtung |
-
2006
- 2006-04-17 JP JP2006113920A patent/JP5044138B2/ja not_active Expired - Fee Related
-
2007
- 2007-04-10 US US11/783,562 patent/US7900578B2/en active Active
- 2007-04-13 DE DE602007013141T patent/DE602007013141D1/de active Active
- 2007-04-13 AT AT07106152T patent/ATE501793T1/de not_active IP Right Cessation
- 2007-04-13 EP EP07106152A patent/EP1870166B1/en not_active Not-in-force
Patent Citations (7)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JPS6179585A (ja) * | 1984-09-28 | 1986-04-23 | ぺんてる株式会社 | ダブルア−ム型ロボツト |
| JPH01281891A (ja) * | 1988-04-30 | 1989-11-13 | Tokico Ltd | 工業用ロボット装置 |
| JPH0283056A (ja) * | 1988-09-20 | 1990-03-23 | Tokico Ltd | 工業用ロボットへのワーク供給装置 |
| JPH10329178A (ja) * | 1997-06-02 | 1998-12-15 | Souki Sekkei:Kk | 射出成形品取出装置 |
| JP2002362738A (ja) * | 2001-06-04 | 2002-12-18 | Jel:Kk | 搬送アーム |
| JP2004217375A (ja) * | 2003-01-15 | 2004-08-05 | Kawasaki Heavy Ind Ltd | 搬送装置および加工設備 |
| JP2004291112A (ja) * | 2003-03-26 | 2004-10-21 | Hitachi Kiden Kogyo Ltd | 移載機 |
Cited By (7)
| Publication number | Priority date | Publication date | Assignee | Title |
|---|---|---|---|---|
| JP2015044638A (ja) * | 2013-08-27 | 2015-03-12 | 川崎重工業株式会社 | ワーク搬送装置 |
| JP2018103117A (ja) * | 2016-12-27 | 2018-07-05 | ダイハツ工業株式会社 | 塗装ブース |
| KR102199834B1 (ko) * | 2020-06-22 | 2021-01-07 | 우태광 | 도장 시스템 |
| CN112892969A (zh) * | 2021-01-18 | 2021-06-04 | 日照中意华坤金属制造有限公司 | 一种铁艺制品加工用喷漆装置及工艺 |
| CN112892969B (zh) * | 2021-01-18 | 2023-02-28 | 日照中意华坤金属制造有限公司 | 一种铁艺制品加工用喷漆装置 |
| WO2025206140A1 (ja) * | 2024-03-28 | 2025-10-02 | 川崎重工業株式会社 | 塗装システム |
| JP7833226B1 (ja) * | 2025-06-06 | 2026-03-19 | コネクテッドロボティクス株式会社 | 保持システム、及びプログラム |
Also Published As
| Publication number | Publication date |
|---|---|
| EP1870166B1 (en) | 2011-03-16 |
| EP1870166A2 (en) | 2007-12-26 |
| DE602007013141D1 (de) | 2011-04-28 |
| JP5044138B2 (ja) | 2012-10-10 |
| EP1870166A3 (en) | 2008-12-10 |
| US20070243075A1 (en) | 2007-10-18 |
| ATE501793T1 (de) | 2011-04-15 |
| US7900578B2 (en) | 2011-03-08 |
Similar Documents
| Publication | Publication Date | Title |
|---|---|---|
| JP5044138B2 (ja) | 搬送システムおよび加工設備 | |
| KR101518105B1 (ko) | 반송 장치 및 로봇 시스템 | |
| CN103204379B (zh) | 搬运装置和机器人系统 | |
| JP3999712B2 (ja) | 多関節ロボット | |
| CN102105375B (zh) | 板状工件的移送设备及移送方法 | |
| KR102044376B1 (ko) | 엔드 이펙터, 로봇 및 로봇의 작업 방법 | |
| CN109277229B (zh) | 机器人系统 | |
| US8231117B2 (en) | Robot system | |
| WO2019213617A1 (en) | Robotic painting booth and operating method | |
| JP2008213060A (ja) | 多関節ロボット | |
| JP7147475B2 (ja) | 物品移載設備 | |
| US11541532B2 (en) | Carrying device, robot system, production system and control method | |
| JP2009072840A (ja) | ハンドリング装置 | |
| TWI675728B (zh) | 機器人及機器人系統 | |
| CA1307306C (en) | Industrial robot device | |
| JP5421172B2 (ja) | 溶接ライン | |
| JP5085615B2 (ja) | 被塗装物保持ロボットおよび塗装用ロボットシステム | |
| WO2014024690A1 (ja) | 産業用ロボット | |
| JP4190631B2 (ja) | 搬送装置 | |
| CN112850355B (zh) | 机器人系统、搬运装置及布线方法 | |
| JPH09216180A (ja) | 半導体ウェハカセット搬送システム | |
| JPH06320363A (ja) | 部品自動組立装置 | |
| KR20210009998A (ko) | 워크탑재 반송장치를 활용한 로봇시스템 | |
| JP2025112202A (ja) | パレット及びロボットシステム | |
| US20130133189A1 (en) | Robot system and method of manufacturing workpiece |
Legal Events
| Date | Code | Title | Description |
|---|---|---|---|
| A621 | Written request for application examination |
Free format text: JAPANESE INTERMEDIATE CODE: A621 Effective date: 20081114 |
|
| A977 | Report on retrieval |
Free format text: JAPANESE INTERMEDIATE CODE: A971007 Effective date: 20110729 |
|
| A131 | Notification of reasons for refusal |
Free format text: JAPANESE INTERMEDIATE CODE: A131 Effective date: 20111227 |
|
| A521 | Request for written amendment filed |
Free format text: JAPANESE INTERMEDIATE CODE: A523 Effective date: 20120223 |
|
| A131 | Notification of reasons for refusal |
Free format text: JAPANESE INTERMEDIATE CODE: A131 Effective date: 20120605 |
|
| A521 | Request for written amendment filed |
Free format text: JAPANESE INTERMEDIATE CODE: A523 Effective date: 20120622 |
|
| TRDD | Decision of grant or rejection written | ||
| A01 | Written decision to grant a patent or to grant a registration (utility model) |
Free format text: JAPANESE INTERMEDIATE CODE: A01 Effective date: 20120710 |
|
| A01 | Written decision to grant a patent or to grant a registration (utility model) |
Free format text: JAPANESE INTERMEDIATE CODE: A01 |
|
| A61 | First payment of annual fees (during grant procedure) |
Free format text: JAPANESE INTERMEDIATE CODE: A61 Effective date: 20120713 |
|
| R150 | Certificate of patent or registration of utility model |
Ref document number: 5044138 Country of ref document: JP Free format text: JAPANESE INTERMEDIATE CODE: R150 Free format text: JAPANESE INTERMEDIATE CODE: R150 |
|
| FPAY | Renewal fee payment (event date is renewal date of database) |
Free format text: PAYMENT UNTIL: 20150720 Year of fee payment: 3 |
|
| LAPS | Cancellation because of no payment of annual fees |